My robot would be sitting at a table, and it would look down at the objects on that table. It would be able identify the objects on the table: salt, pepper, a can of beer, a knife, a plate a spoon, and carrots on the plate. It would also know the coordinates of each object in 3D space of each object. Knowing that it would reach out and pick up the beer. I think Tensorflow can do some of this already. Microsoft Cognitive vision gives you the objects it sees, but not the locations.





Discover more robots
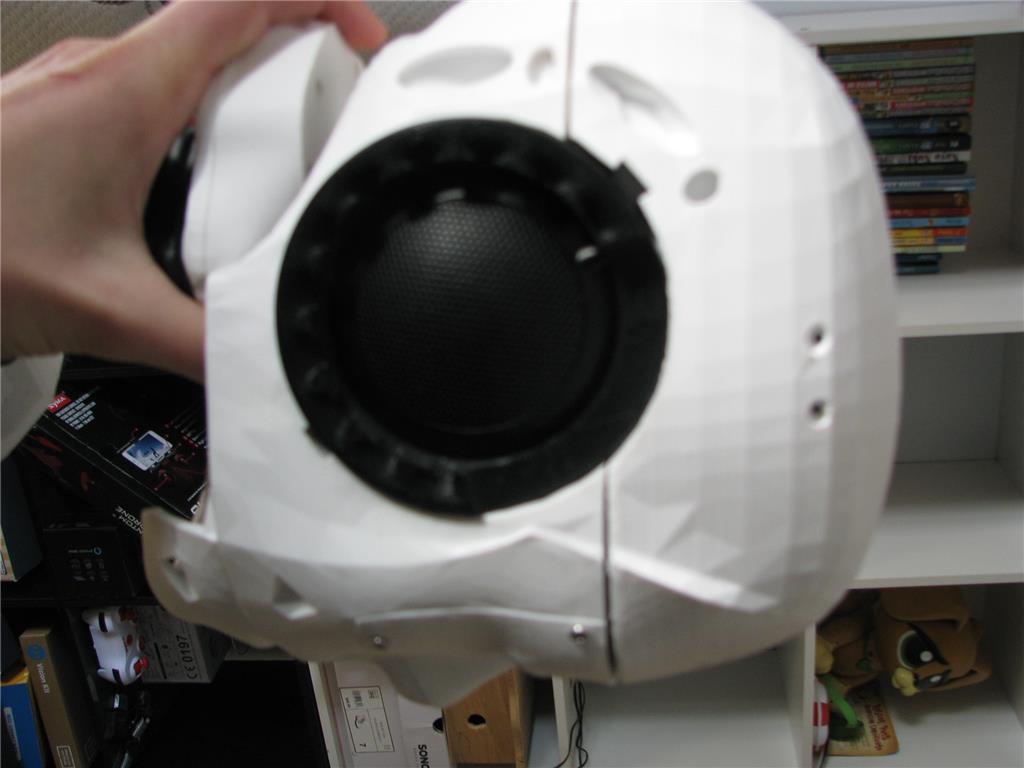
Autiboy's Max The Robot Based Off Of Inmoov
InMoov-based robot Max, fully 3D-printed and assembled; first 3D-printed robot with a FreeCAD-modified custom ear.
Mickey666maus's UNITY LINK / ARC
Link Unity 3D to Synthiam ARC using Flask and Python to send virtual servo positions to real servos, sync motion via COM...
DJ's Omnibot 2000
Omnibot 2000 converted with Synthiam EZ-Builder and EZ-Robot kit: servos, camera, speech, glyph vision, autonomous or...
