
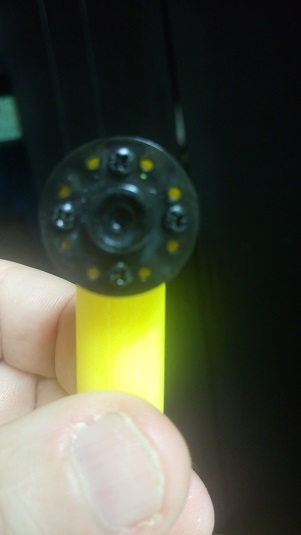
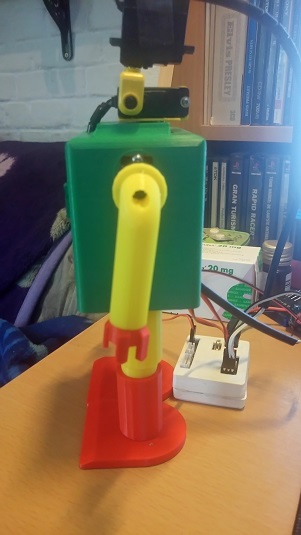
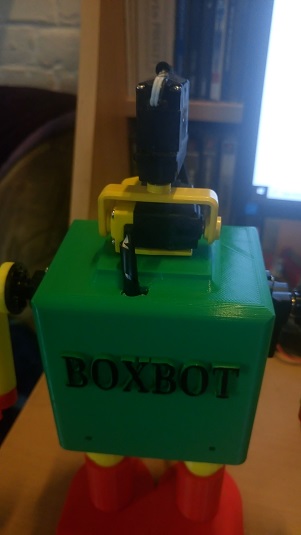
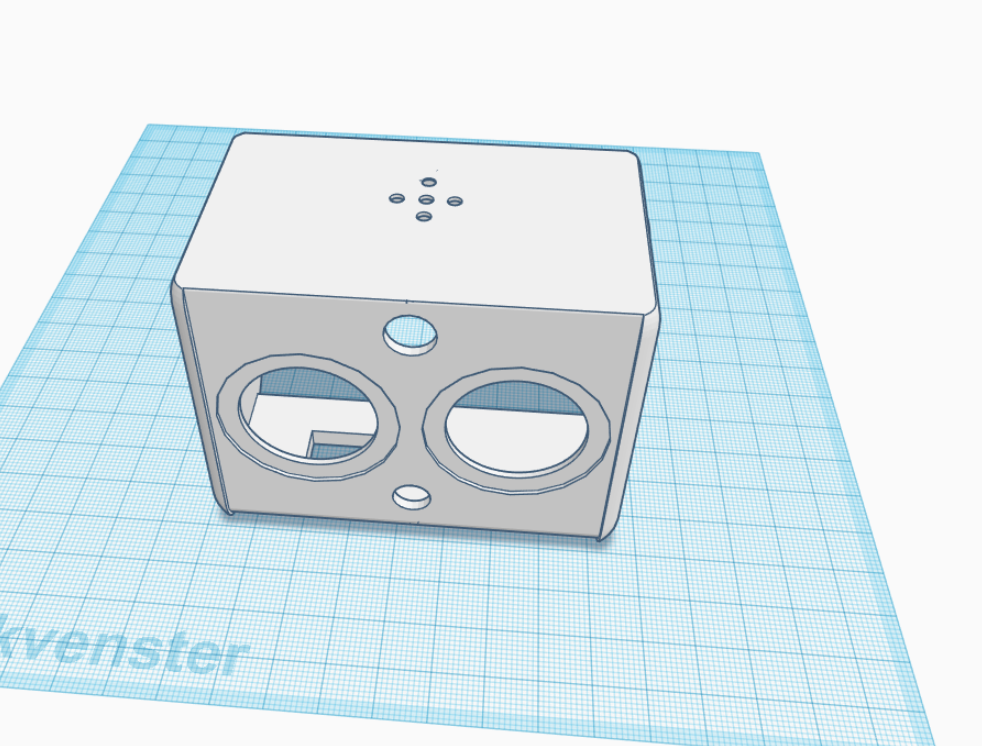
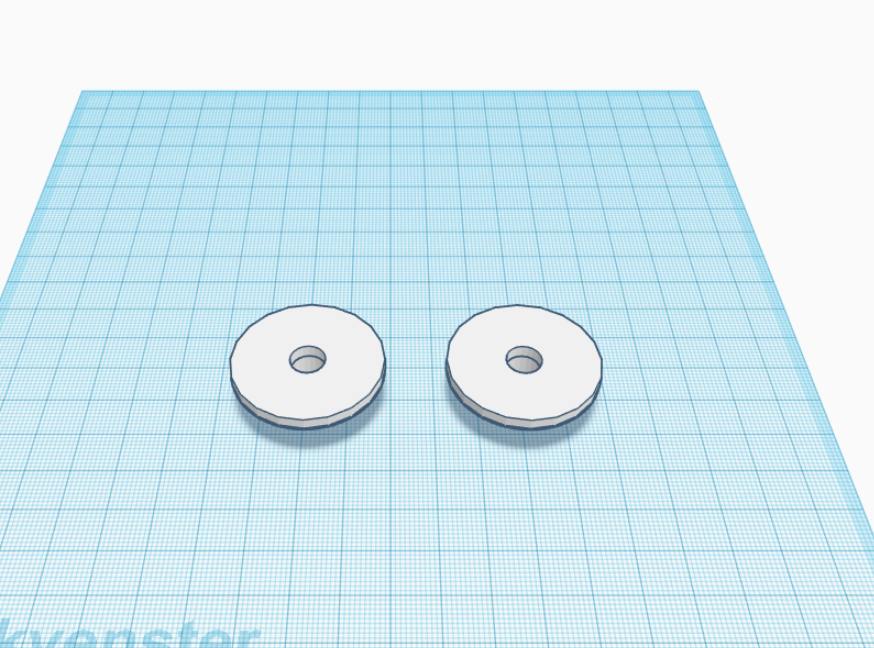
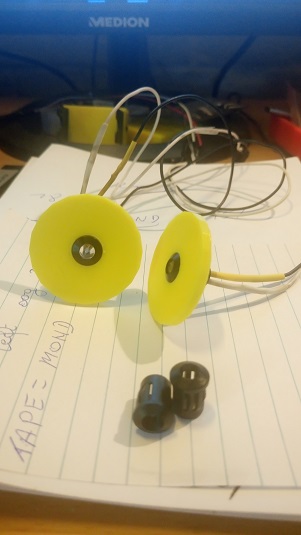
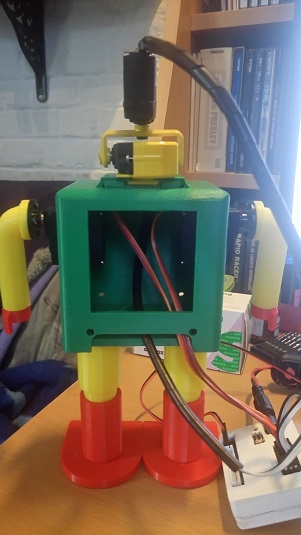
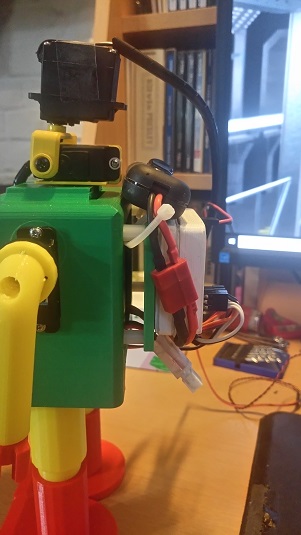
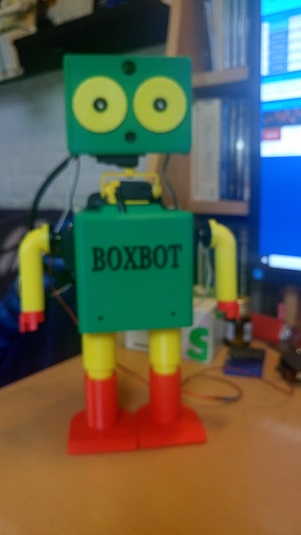
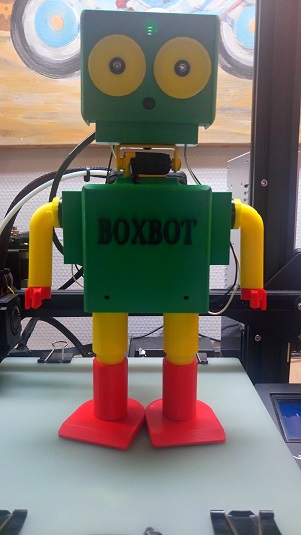
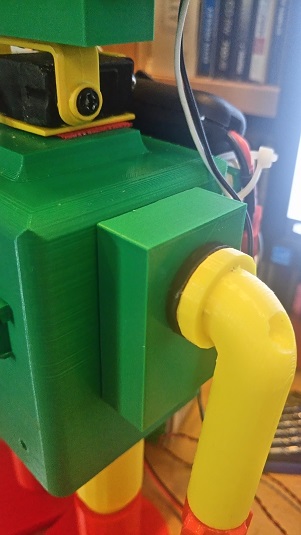
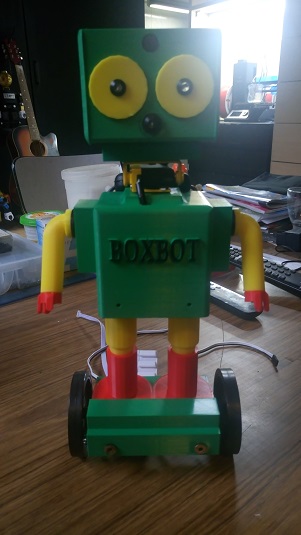
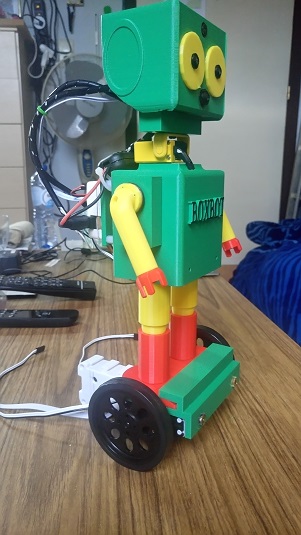
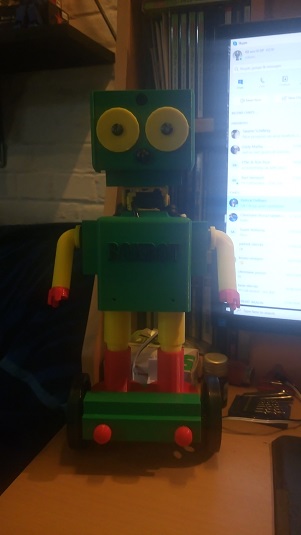
P2 stands for printed second version boxbot.cause dj made the first boxbot. the V1 stands for version 1.version V2 will get some wheels. this robot is a desk robot to train excample camera /position movements and more. it has 4 micro servo's camera still to come ,two flat eye LED blue. the red covers lowerlegs are changeble i, other colors. still need to do .head to print/camera /choulder covers (servo's )
By Nomad 6R
— Last update


Discover more robots
JT's Jts Robie Sr.
Restoring a Robie SR for EZ-B-ification: raising height ~6 in, adding a turning/tilting neck, new paint, learning...
DJ's Philo Junior Color Tracking Test
Control Philo Junior with Synthiam ARC camera 'Track By Relative Position' and WiiMote for simple, cost-effective,...
Sbesk's First Ever Robot. Ish
Build and program a lightweight EZ-B3 quadruped with EZ-Builder; tips on 7.4V 800mAh LiPo hookup, servos, batteries and...

shoulder covers and neck cover are reddy.
My god!!!! So cute!!!!!
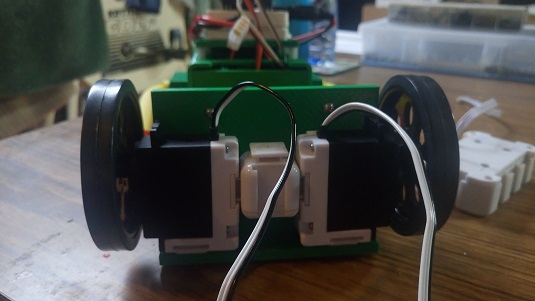
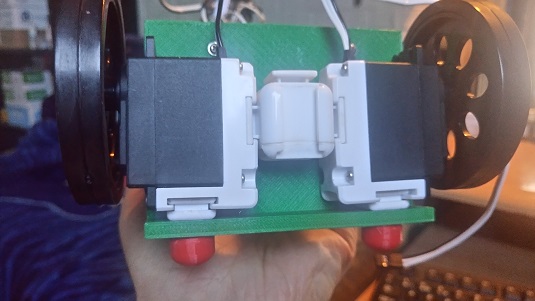
here's the wheel plate.using the ez robot wheel servo's.
you can see the two tiny screws to keep the feets inside the plate. inside front plate are the two squerre and spindel.
waiting for parts DUH.
Your robot is looking good Nomad, Does he have a name?
I just got back from my other life , the country / farm life - back to the city.
when will a video be coming of your robot? Keep me posted
thanks again EzAng
hi ezang
the name is boxbot p2-v1 comes from p2 means printed and two means second boxbot. dj made the first one in cardboard.v1 stands for version 1 to make a video i need this sensor,
sensor
here you can see how the wheel servo's are connected to the wheel plate.
Nice job on the wheel base. Makes for a nice finish to the build. Will be cool to see it roaming around.
nice job Nomad, waiting for your video.
EzAng