
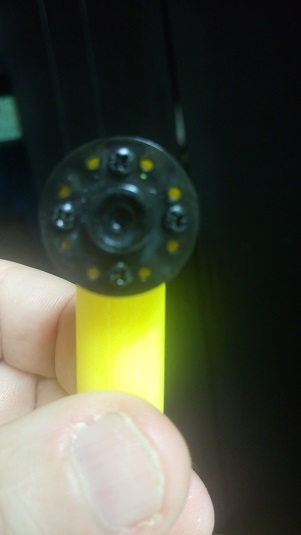
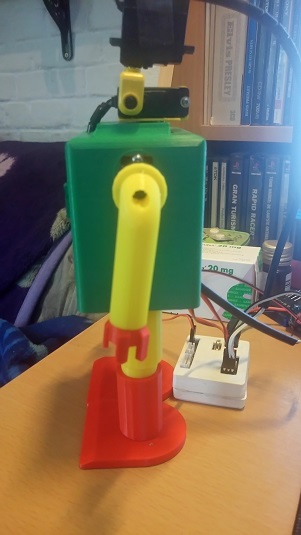
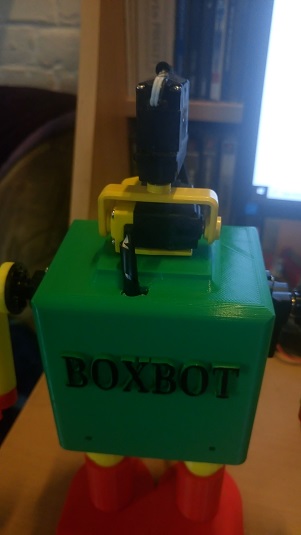
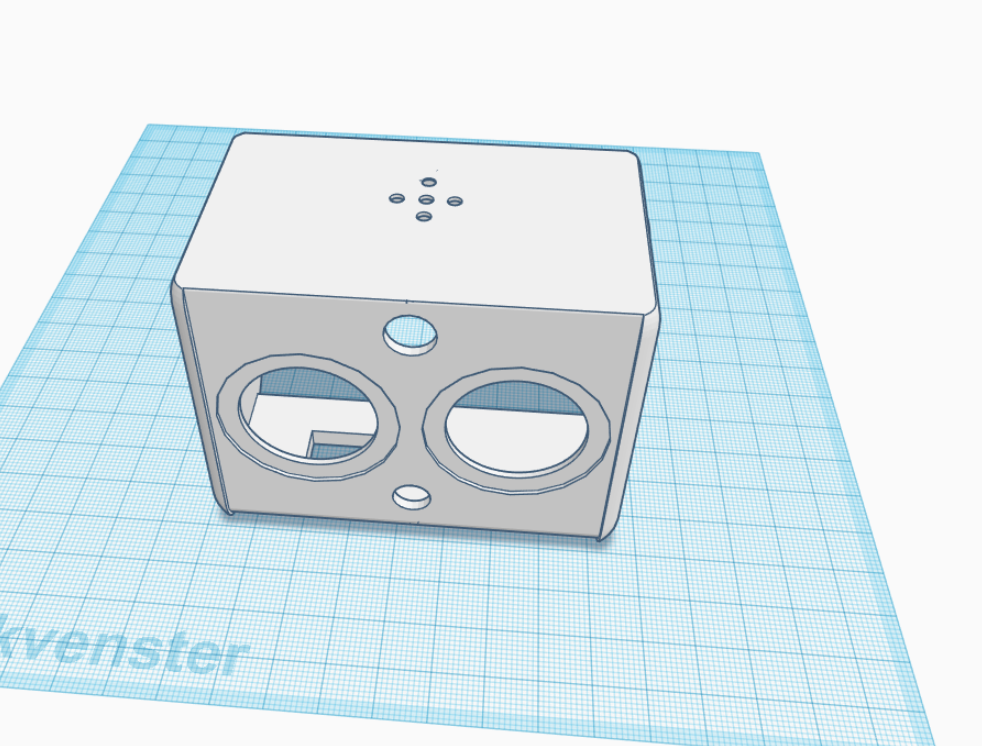
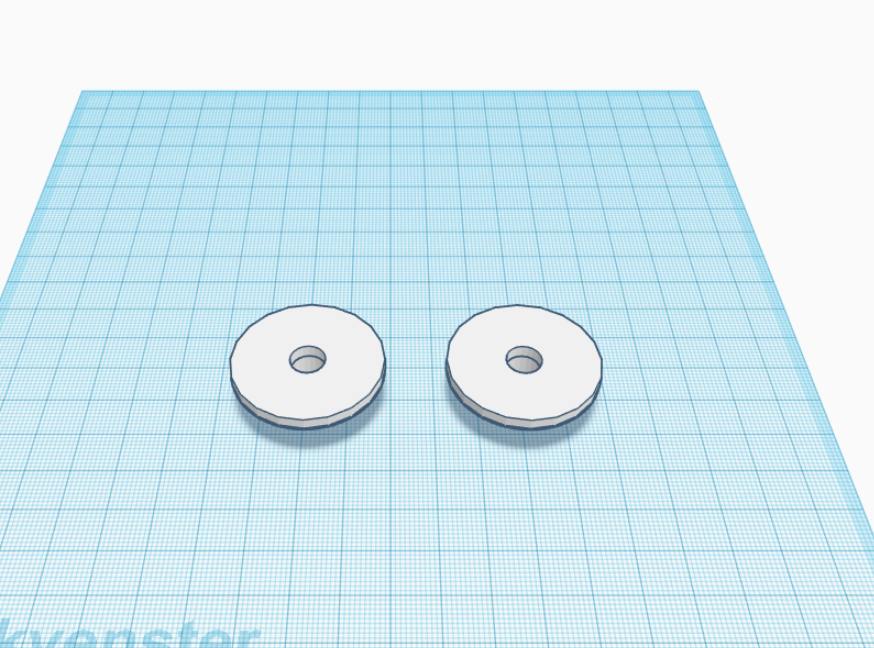
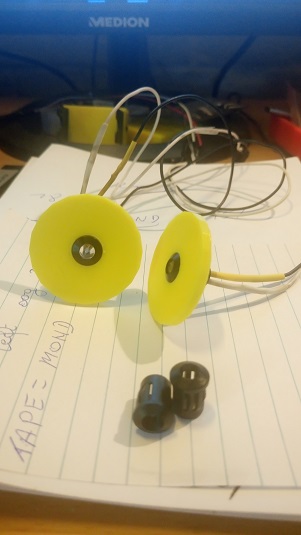
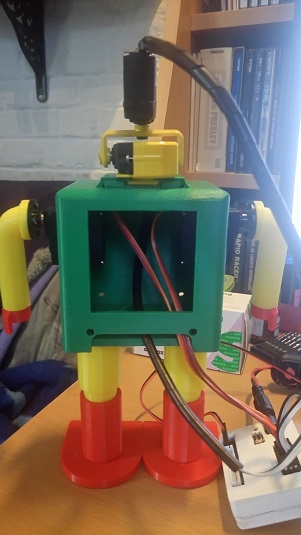
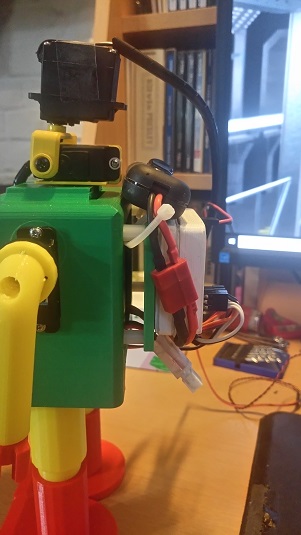
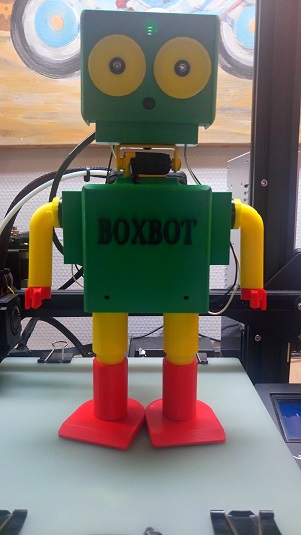
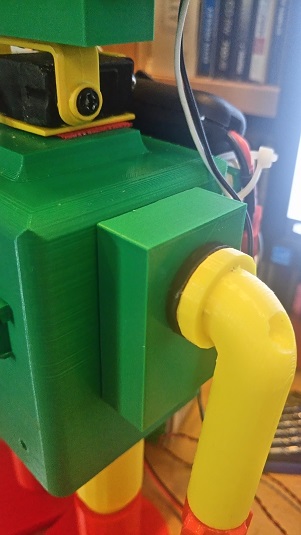
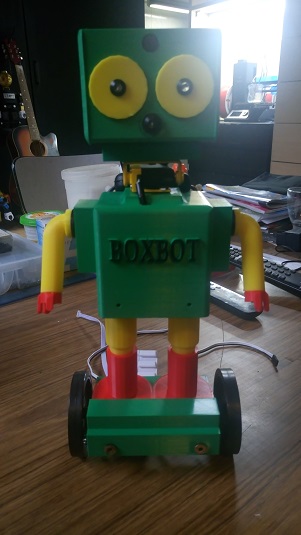
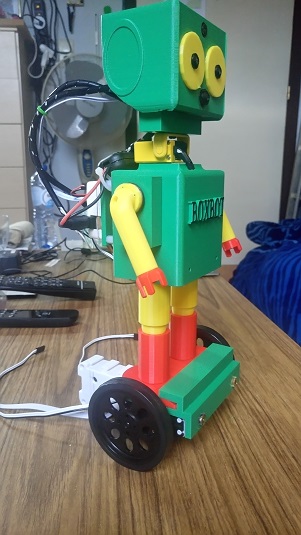
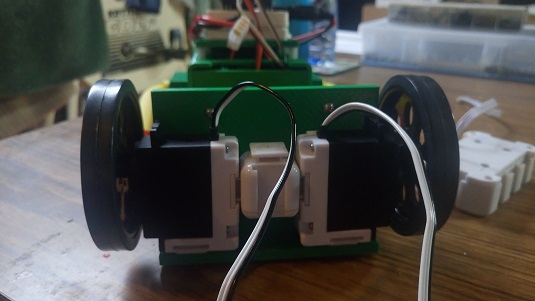
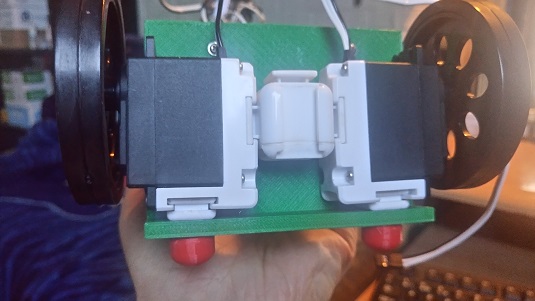
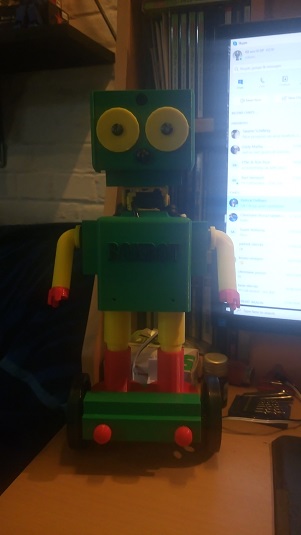
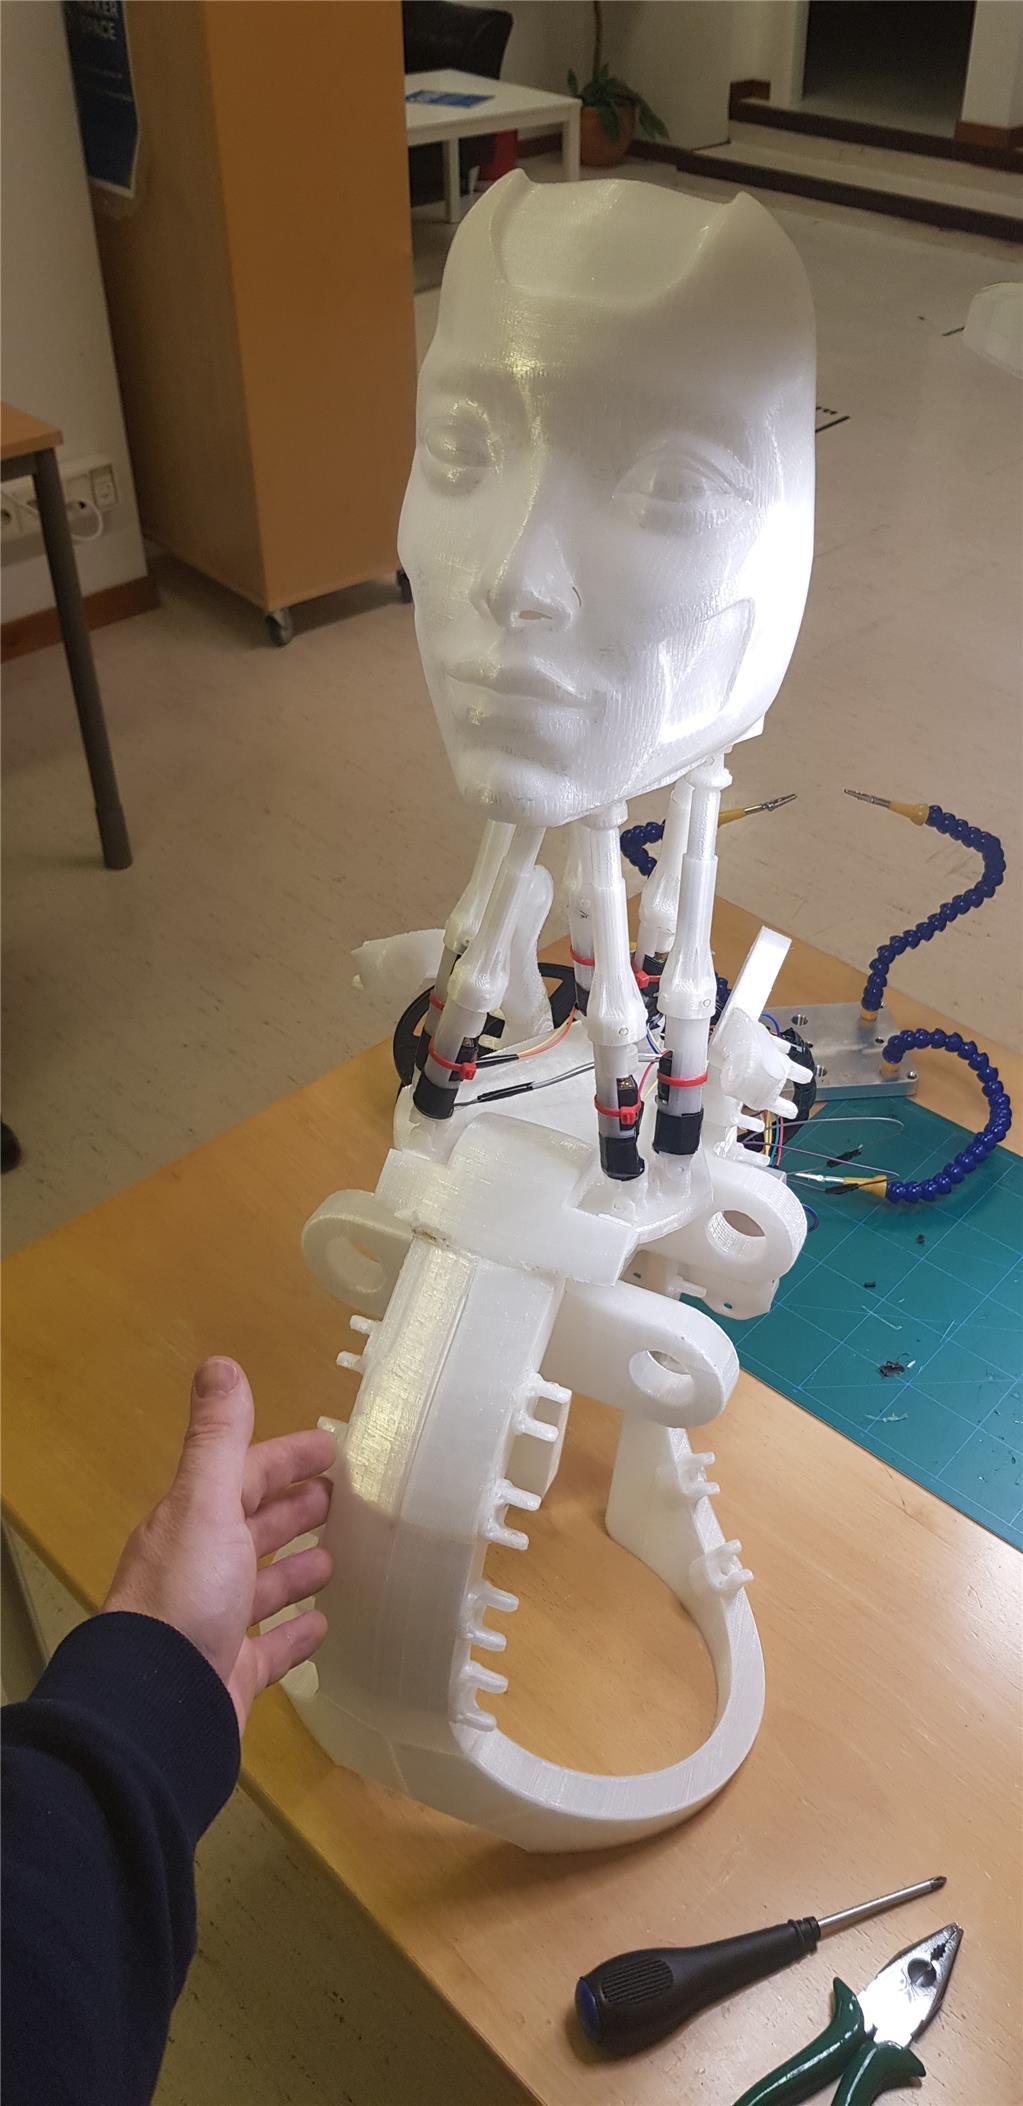
P2 stands for printed second version boxbot.cause dj made the first boxbot. the V1 stands for version 1.version V2 will get some wheels. this robot is a desk robot to train excample camera /position movements and more. it has 4 micro servo's camera still to come ,two flat eye LED blue. the red covers lowerlegs are changeble i, other colors. still need to do .head to print/camera /choulder covers (servo's )
By Nomad 6R
— Last update


Discover more robots
Luis's Using A Mq-? Sensor With The Ezb4 And ARC
Demo video posted-watch the demo and enjoy; creator happy to answer any questions.
Animator28's AVA (Advanced Visual Android) Update
Synthiam ARC robot build: DLP face animations via EZ-Script/VLC, ezb camera object recognition, H-bridge DC neck...
Oakmot's Chloe Project
Home mannequin robot using EZ-B servos, camera face-tracking and Synthiam ARC control with DC power, arm plans, and...

hey ezang
i am still using PLA.
ok thanks
EzAng
Did you ever use PETG?
no only PLA.no other filaments.
some adjustment are made on the head. there is room for the camera and a little speaker.
I am here, a little slow out here :-)
looks great, my robot friend -
any videos?
EzAng
i have to upload a video.
i am uploading the video now.