
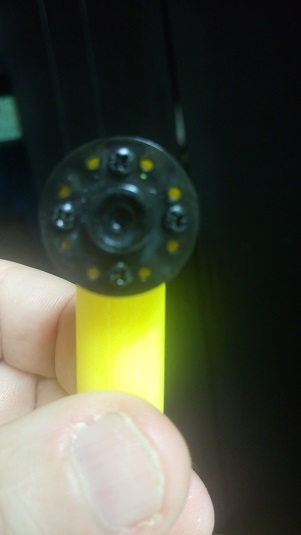
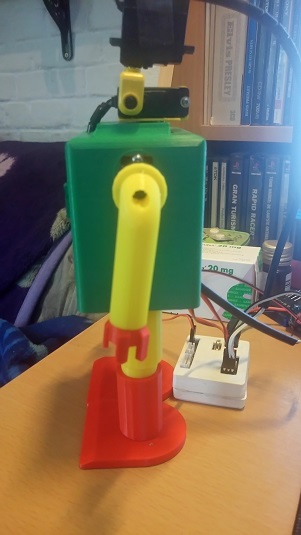
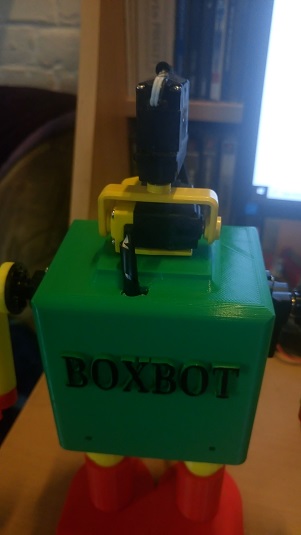
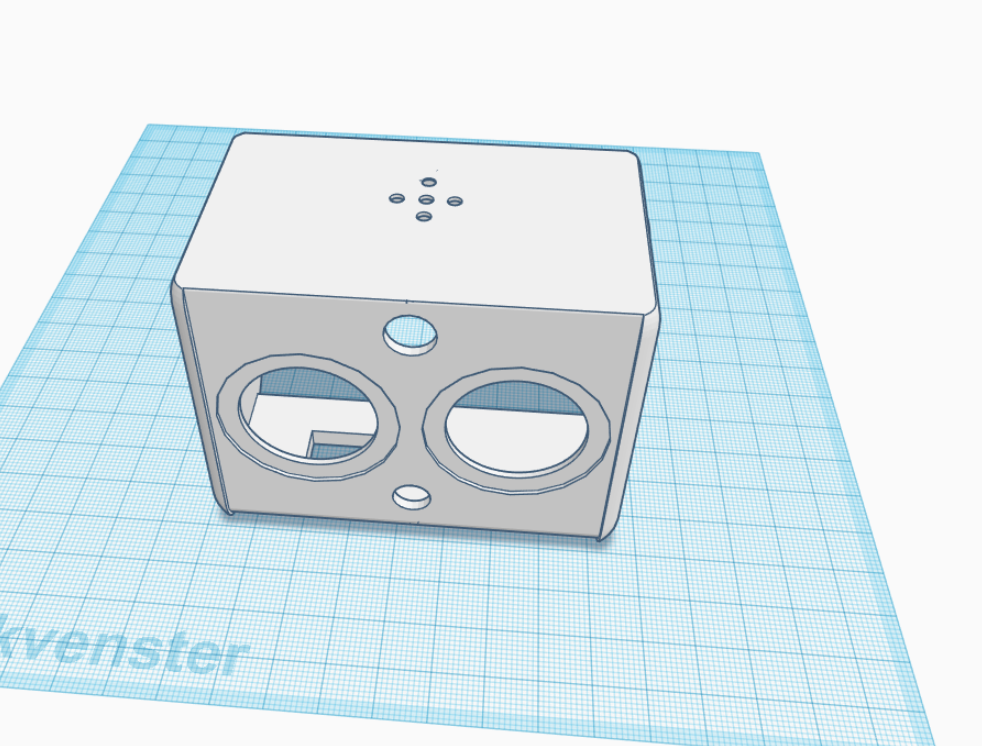
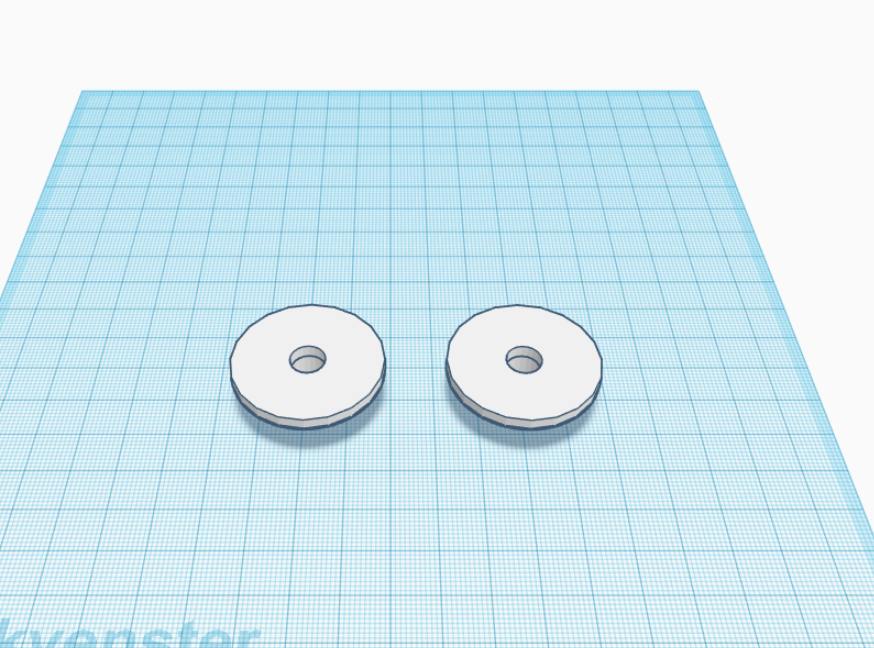
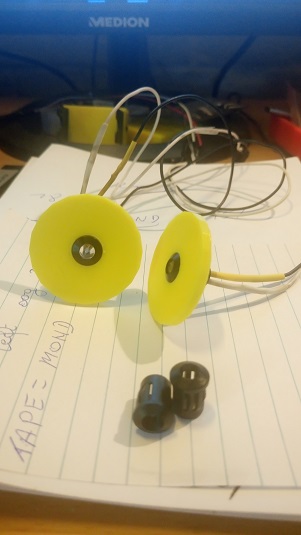
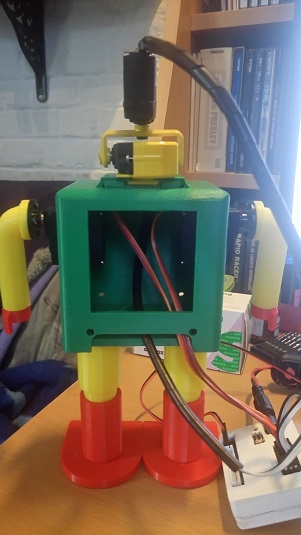
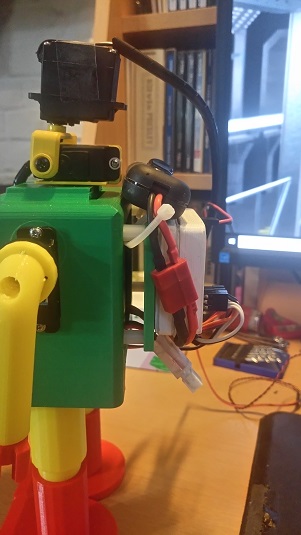
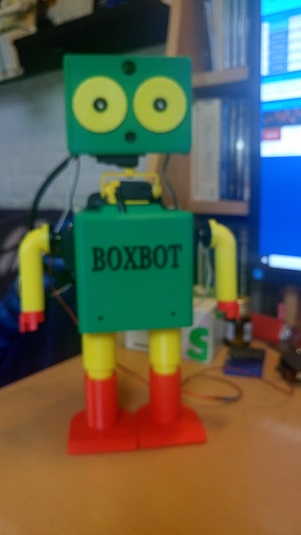
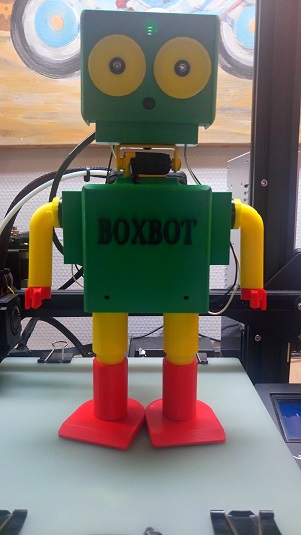
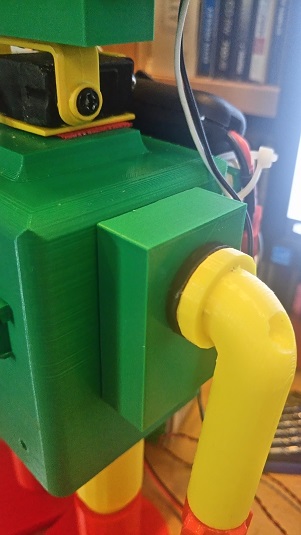
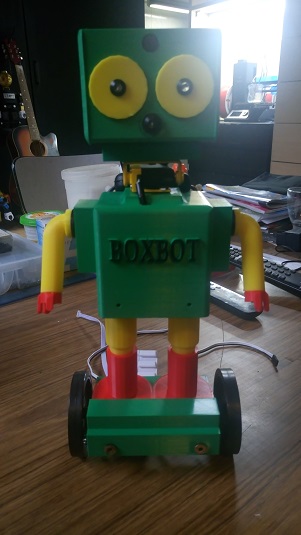
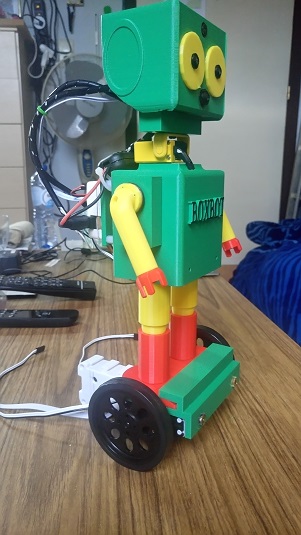
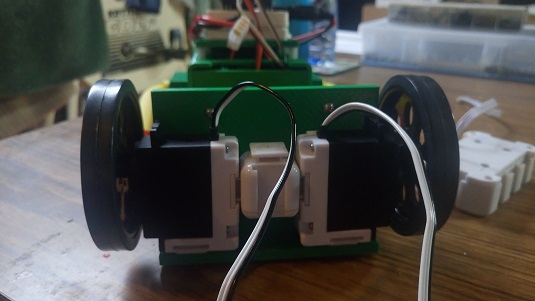
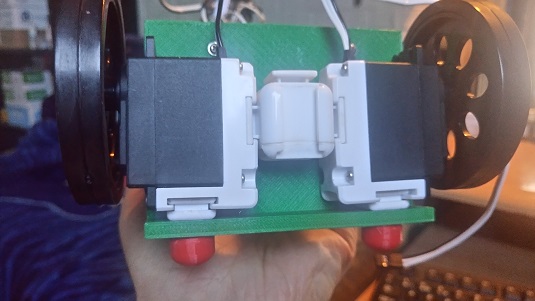
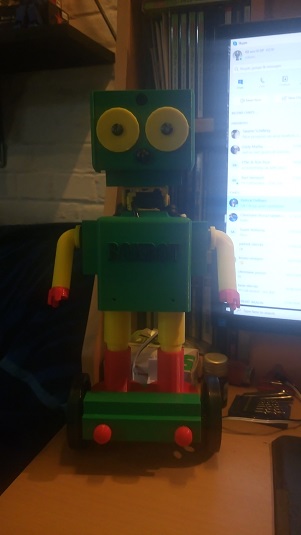
P2 stands for printed second version boxbot.cause dj made the first boxbot. the V1 stands for version 1.version V2 will get some wheels. this robot is a desk robot to train excample camera /position movements and more. it has 4 micro servo's camera still to come ,two flat eye LED blue. the red covers lowerlegs are changeble i, other colors. still need to do .head to print/camera /choulder covers (servo's )
By Nomad 6R
— Last update


Discover more robots
Ezang's Happy New Year To All From Ezang And Family And...
Happy New Year from EzAng, family and Roman the robot, grateful to robot friends for teaching so much and promising more...
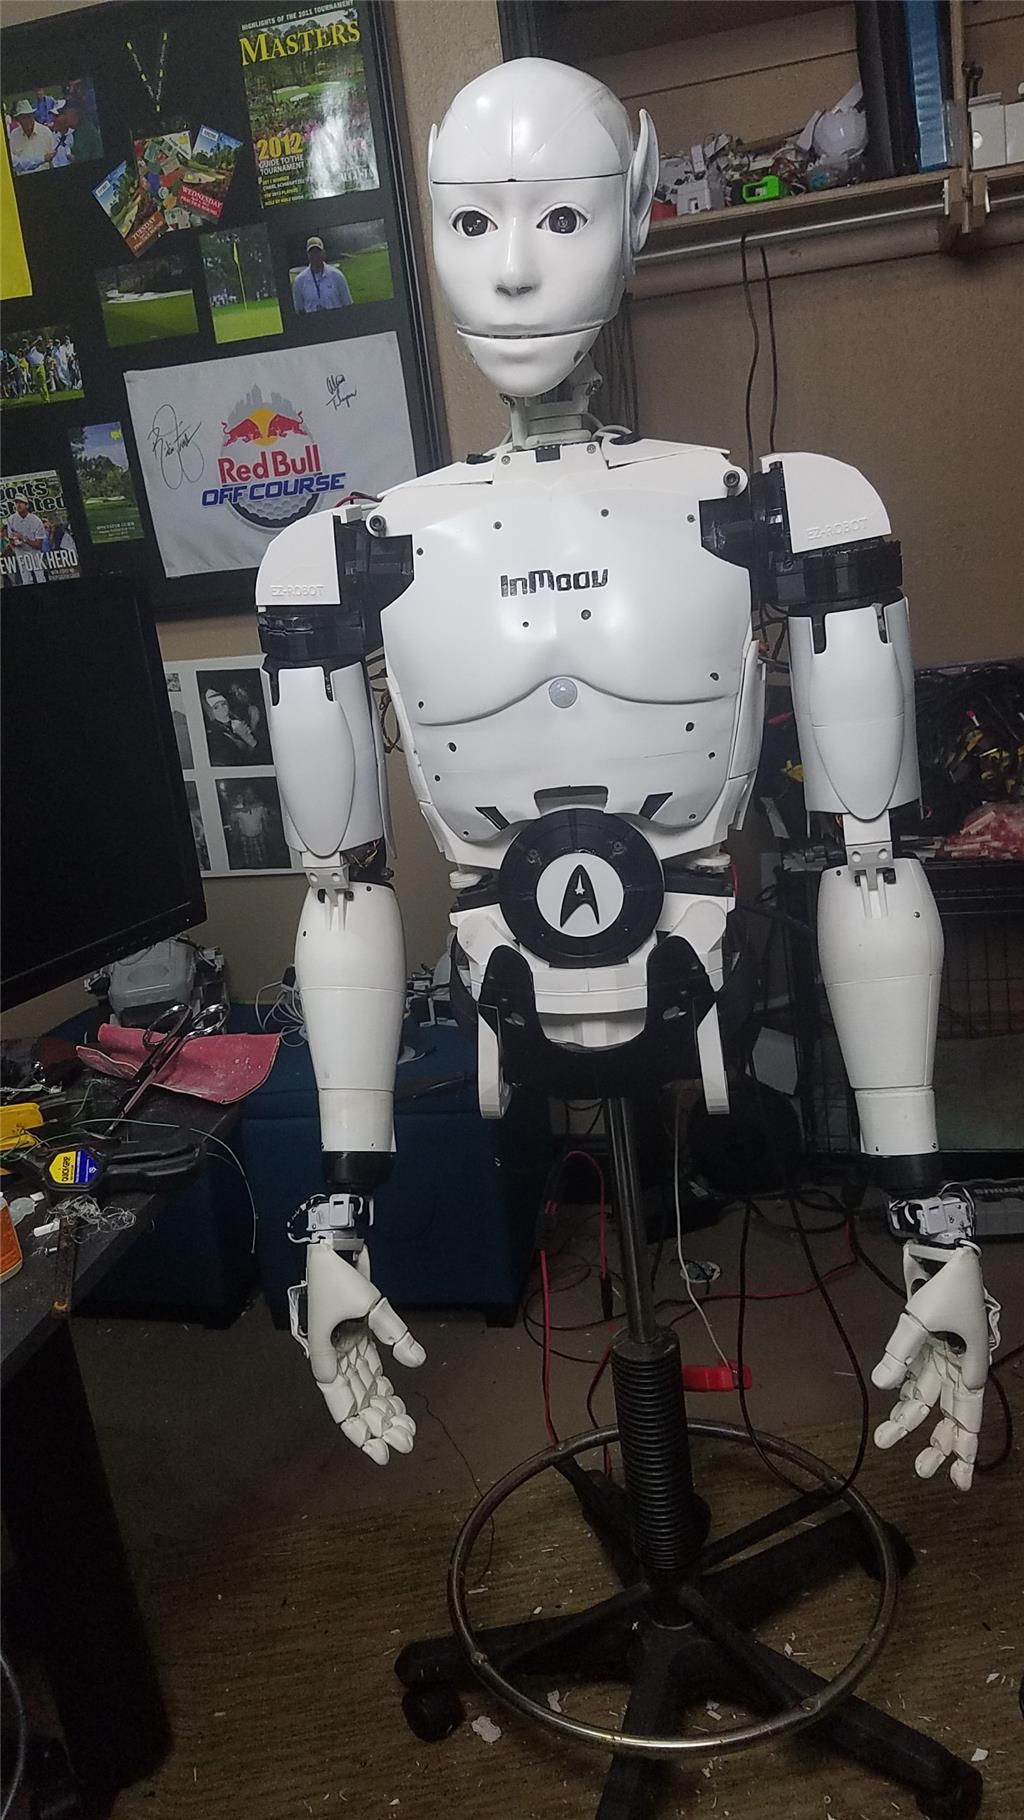
Cochranrobotics's Inmoov - D.Cochran Style
InMoov 'Spock' rebuild using LattePanda, dual EZ-B controllers, Omron HVC-P vision, MXL mic, Flexy hands, BEC power...
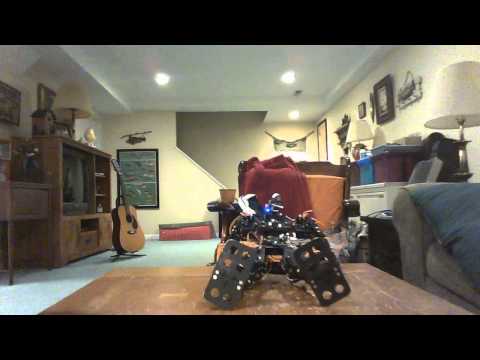
Cliffordkoperski's Cliff Robot
Cliff robot test run showing motion without gyro/accelerometer; future sensor demo planned; affordable Oak Studios servo...

thanks guys.just one part to go.xD