
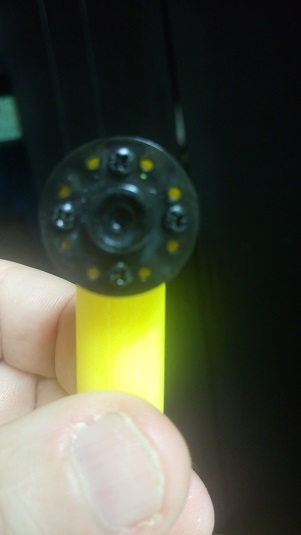
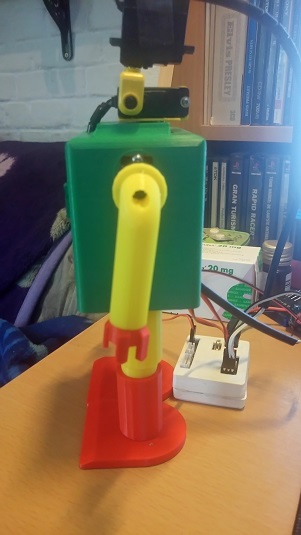
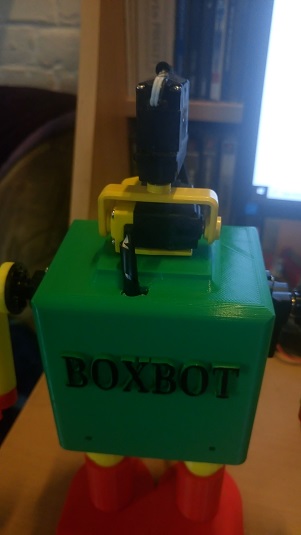
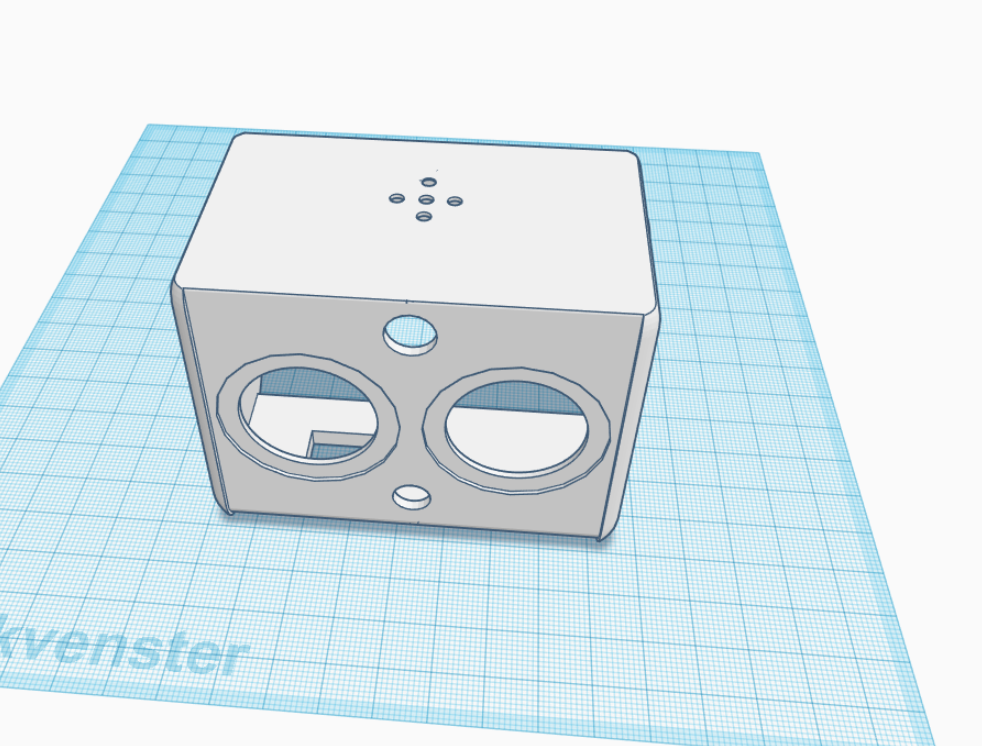
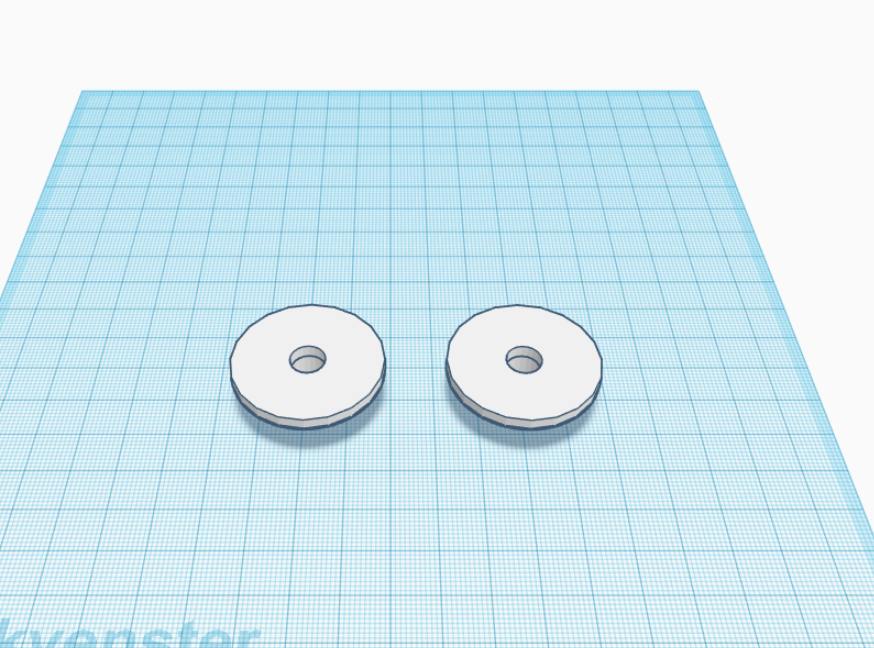
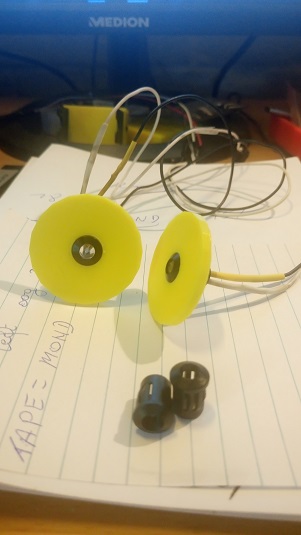
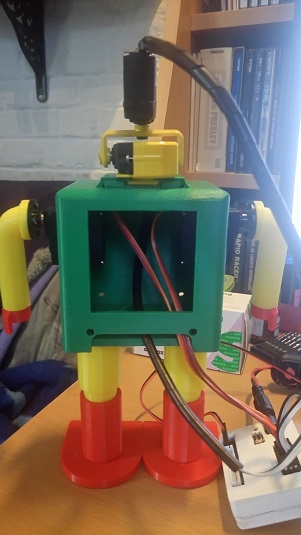
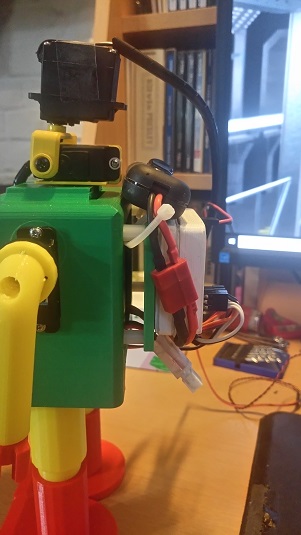
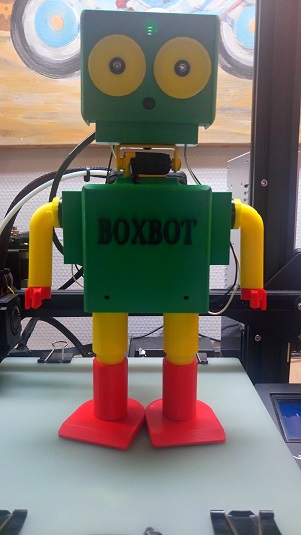
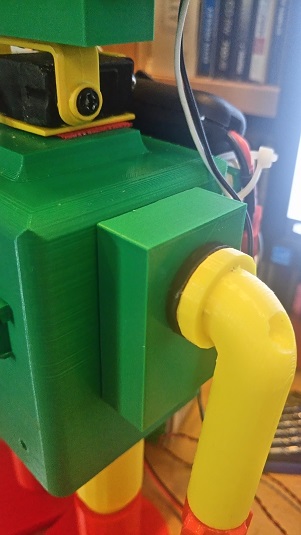
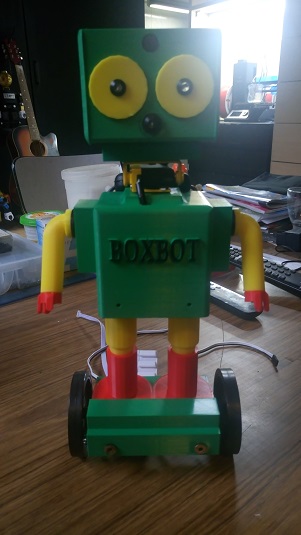
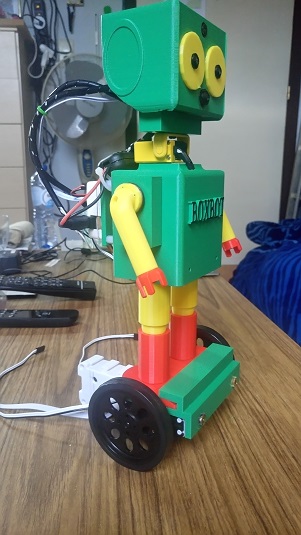
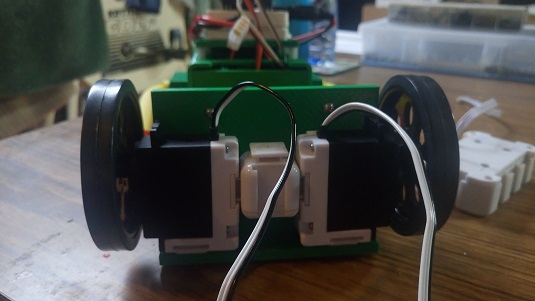
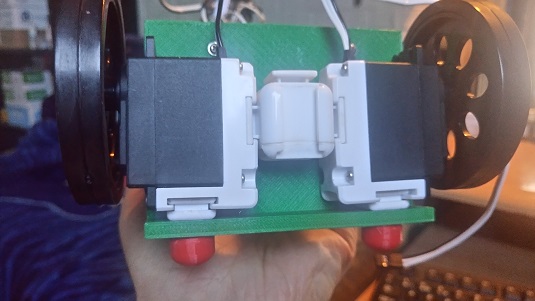
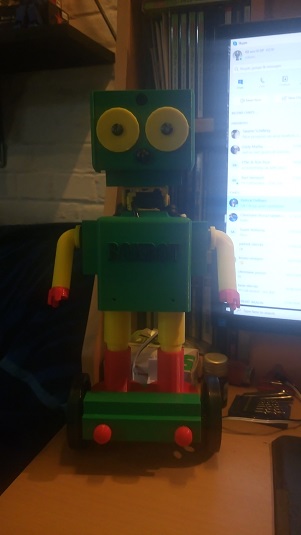
P2 stands for printed second version boxbot.cause dj made the first boxbot. the V1 stands for version 1.version V2 will get some wheels. this robot is a desk robot to train excample camera /position movements and more. it has 4 micro servo's camera still to come ,two flat eye LED blue. the red covers lowerlegs are changeble i, other colors. still need to do .head to print/camera /choulder covers (servo's )
By Nomad 6R
— Last update


Discover more robots
Robohappy's Introducing....HEMI Or HHCB1 (Home Health Care...
HEMI home-health robot prototype lifts and transfers patients using high-torque servos, actuator, sensors, EZ-B control,...
Jphillipsnj's Inmoov Project
InMoov life-size open-source 3D-print robot project using EZ-Robot and EZ Face, exploring Kinect support and VB.net...
Doombot's Archetype Finally Complete
Archetype droid using EZbits and an EZ-B: expandable design, currently on a 2A regulator with supercap fix; battery...

thanks guys.just one part to go.xD