
Hello Athena,
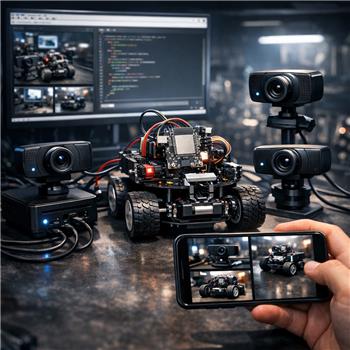
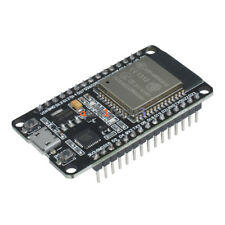
I’m building a robot with an ESP32 configured to drive the motors via its GPIO ports (the ESP32 is acting as the robot’s microcontroller / EZB-level hardware controller). The robot also has a Mini PC running Windows 11, and I am running Synthiam ARC on the Mini PC. I’m using the Camera Device robot skill in my ARC project.
My question: can I connect three USB cameras to the Mini PC (using the Camera Device skill) and still control the robot (via the ESP32) while viewing each of the three camera feeds on my mobile phone?
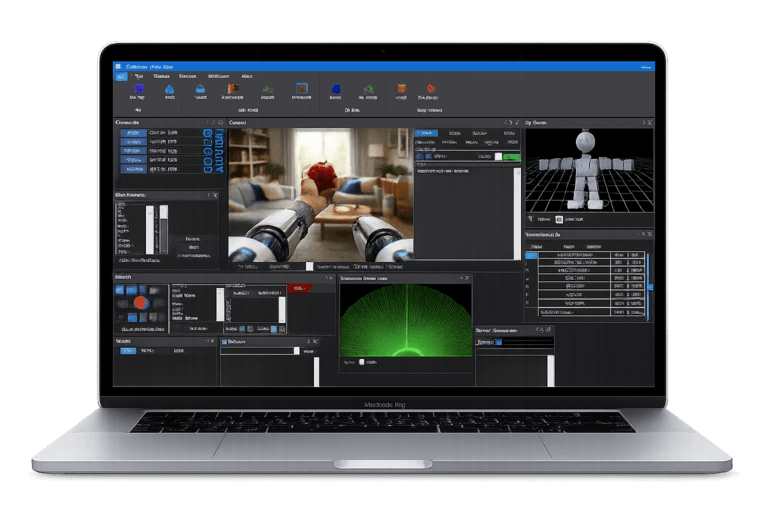
Yes, you can add up to 1024 cameras. However, i do recommend you look into ARCx based on this and your other question. With ARCx, you can run a lightweight Linux OS for embedded computing and remote control via your phone.
Yes - you can run three USB cameras on the Mini PC and still control the robot through the ESP32 in the same project.
How it works
Important best-practice note
For cameras in ARC, the proven approach is to use:
Front CameraLeft CameraRight CameraThen other skills can subscribe to those sources by name.
Things to watch out for
Recommended setup
If you want phone viewing specifically
A browser-accessible interface is usually the cleanest solution. In ARCx, browser windows are built for this kind of setup and can be shown on displays or accessed through the robot’s interface.
See:
My recommendation
If your goal is multiple cameras + mobile remote viewing, ARCx is a better fit than a desktop-only workflow. It’s especially strong for browser-based remote access and lightweight deployment.
Question
Are you trying to view all three cameras at the same time on the phone, or just be able to switch between them?
That changes the best UI approach.