Stop
Movement.stop()
Returns
NothingDescription
Stops the robot using the project's Movement Panel skill.
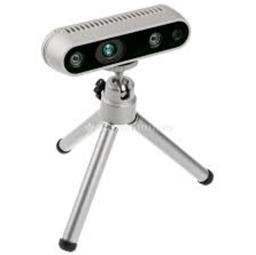 Intel Realsense D435i
— Connect Intel RealSense depth cameras to ARC NMS for depth-based distance detection, point-cloud mapping, video streaming, and navigation telemetry.
Try it →
Movement.stop()
Stops the robot using the project's Movement Panel skill.