cE9s4PsOgeBQIORwjd5!~~60_1-634818020230156250.jpg)
Lupuc4g~~60_35-634706297915000000.jpg)
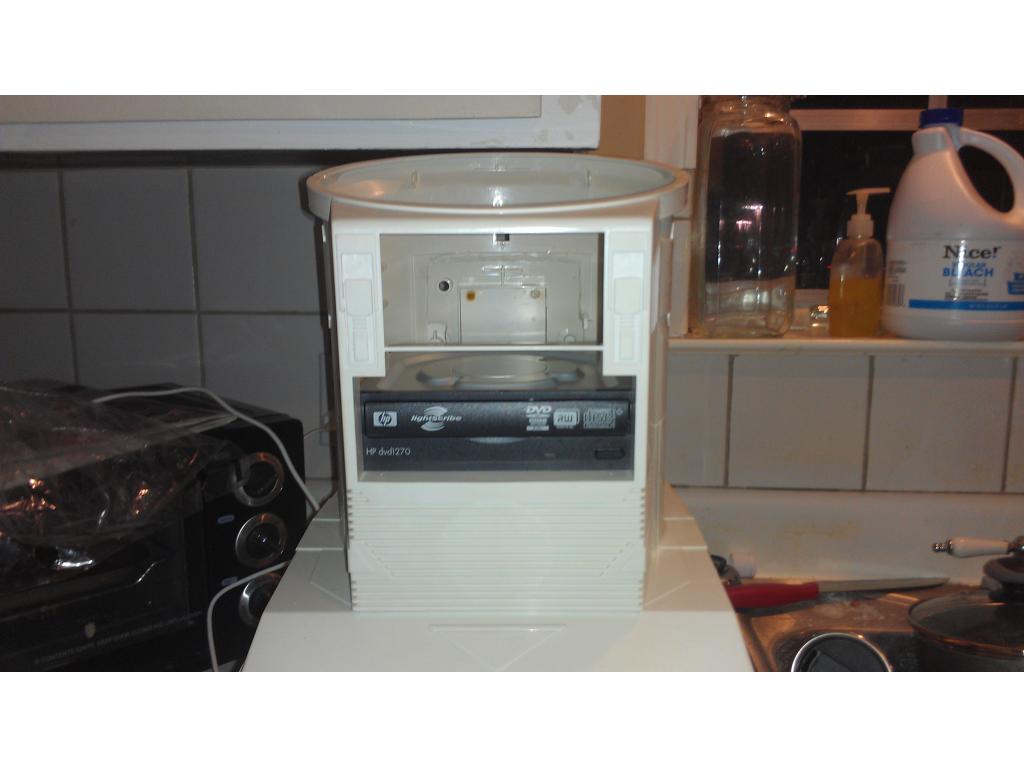
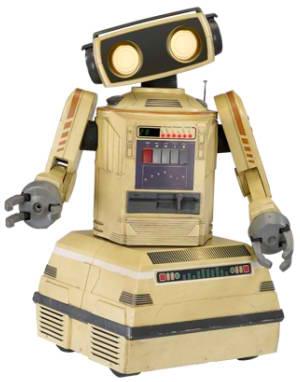
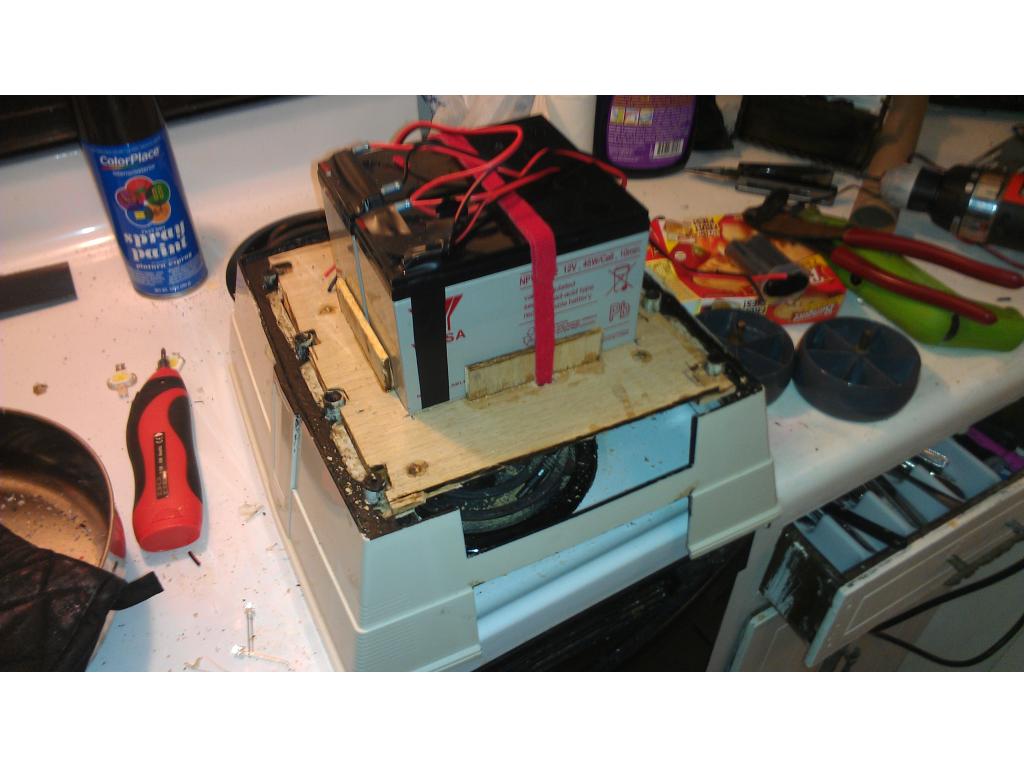
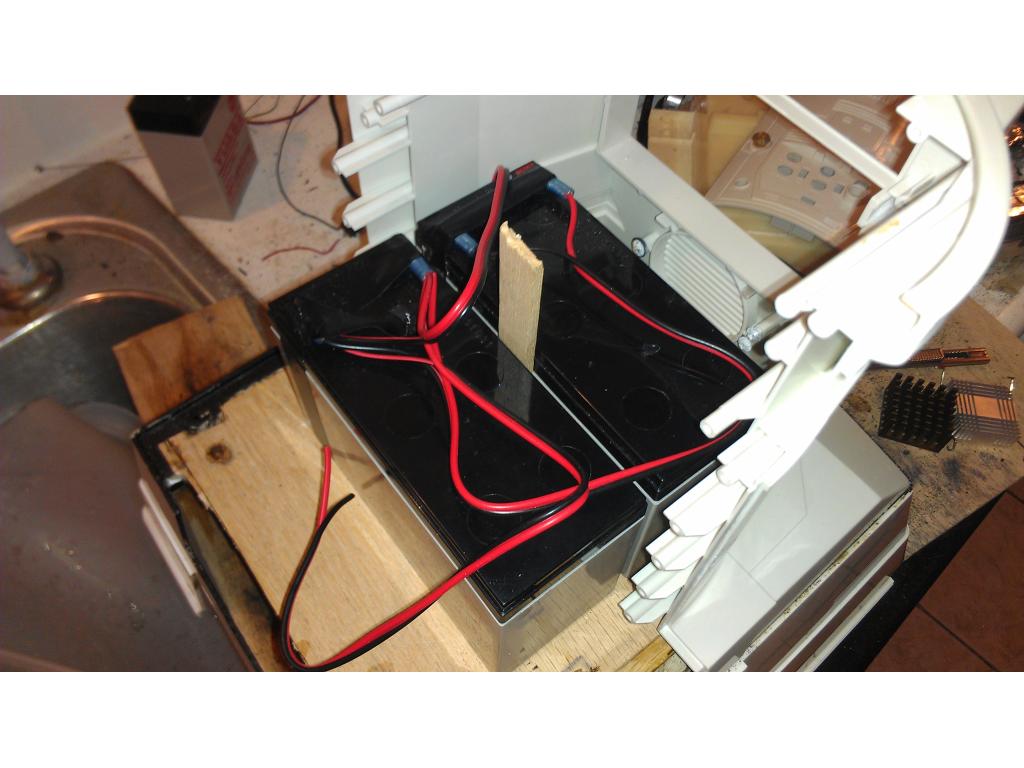
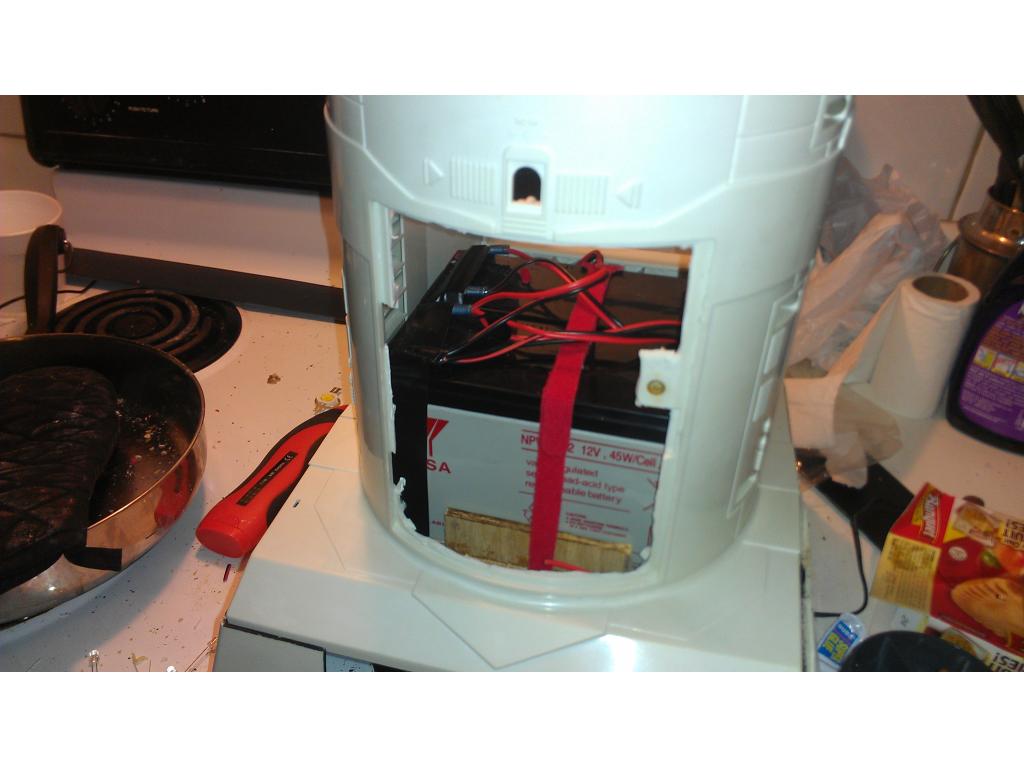
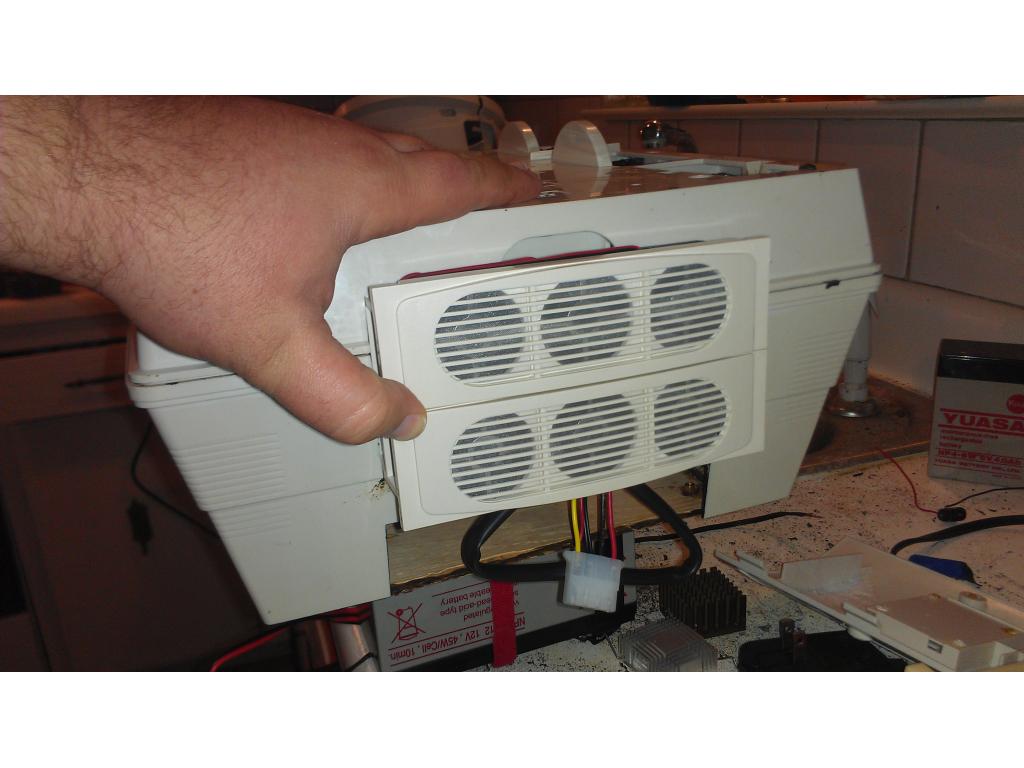
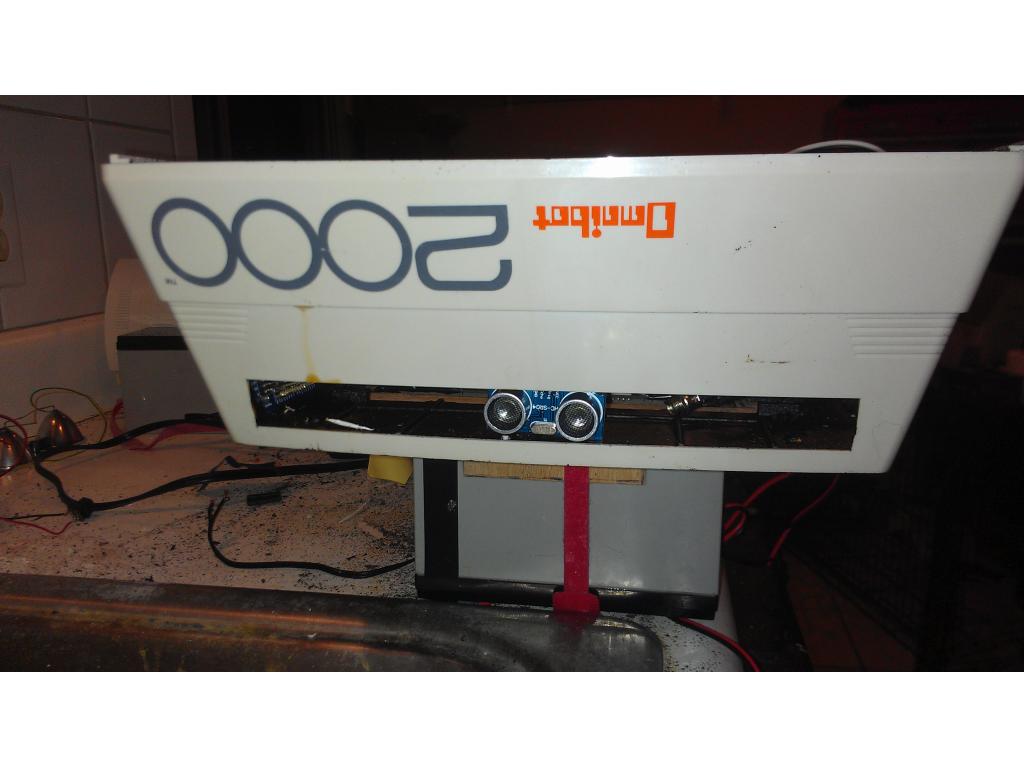
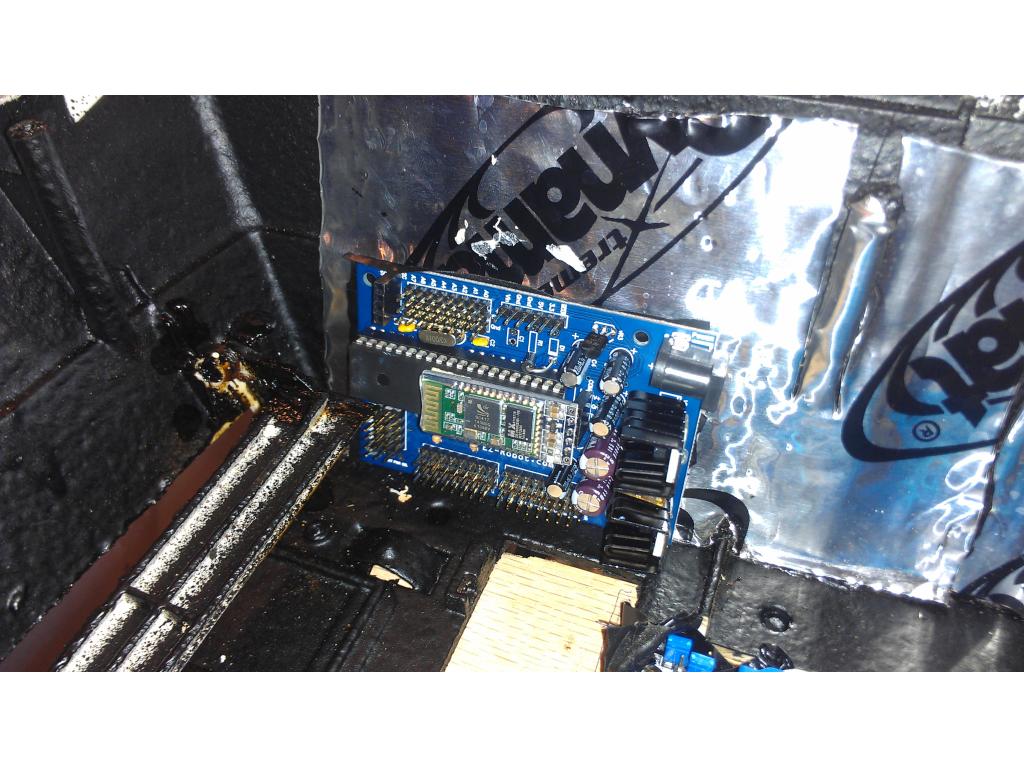
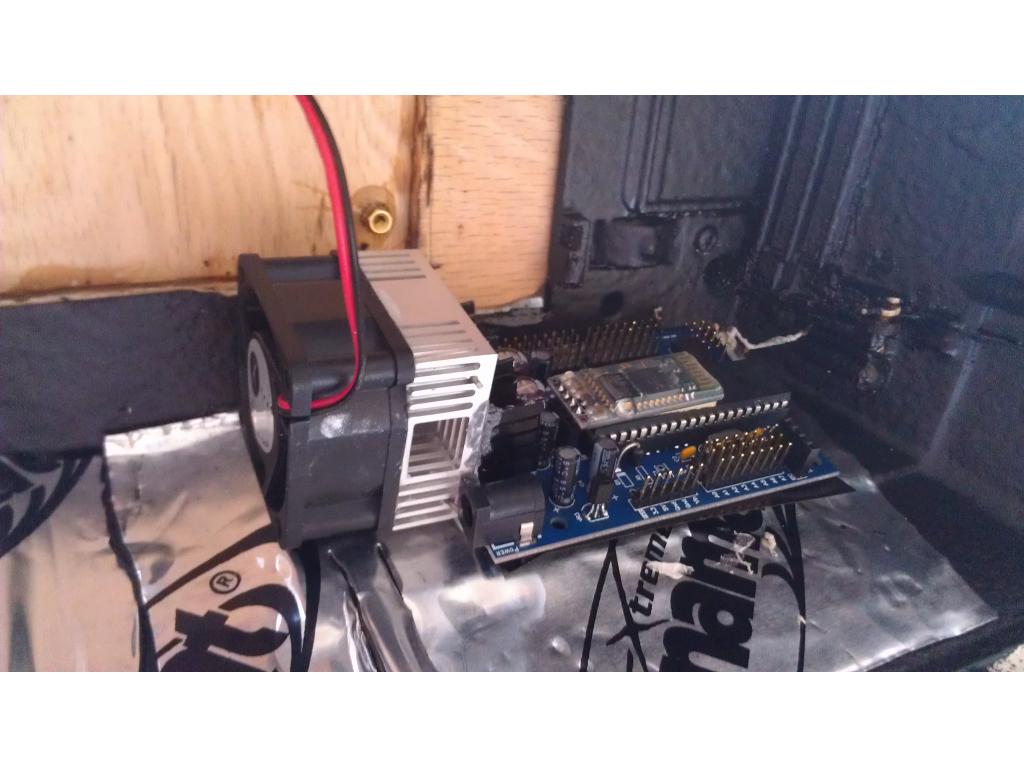
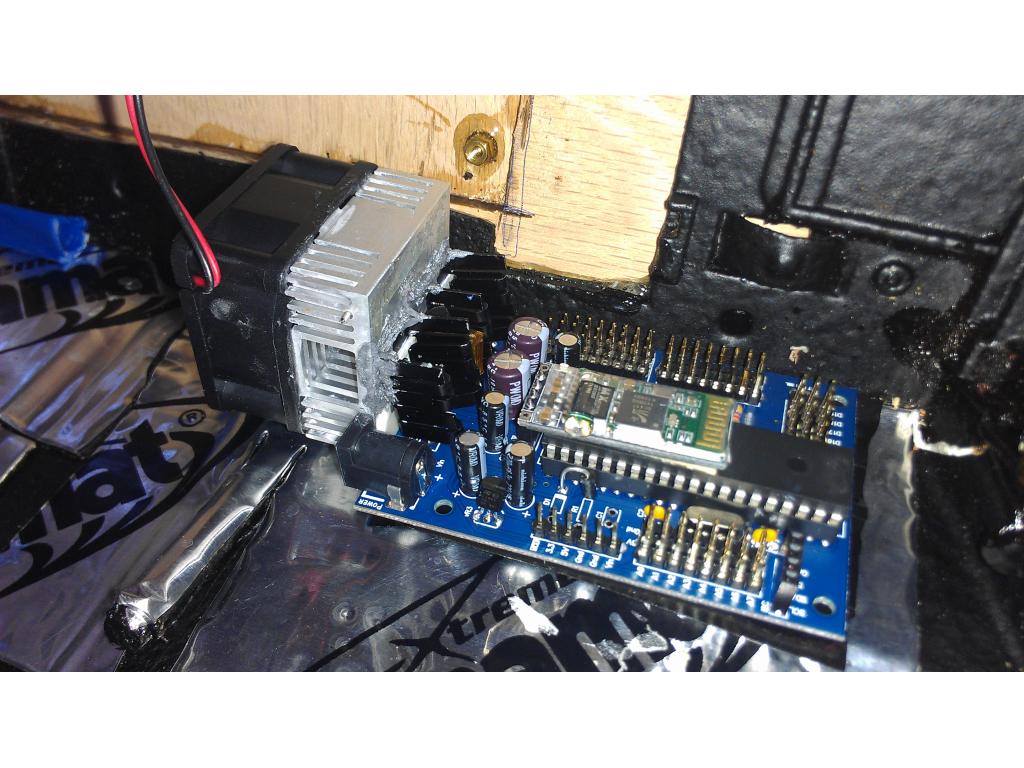
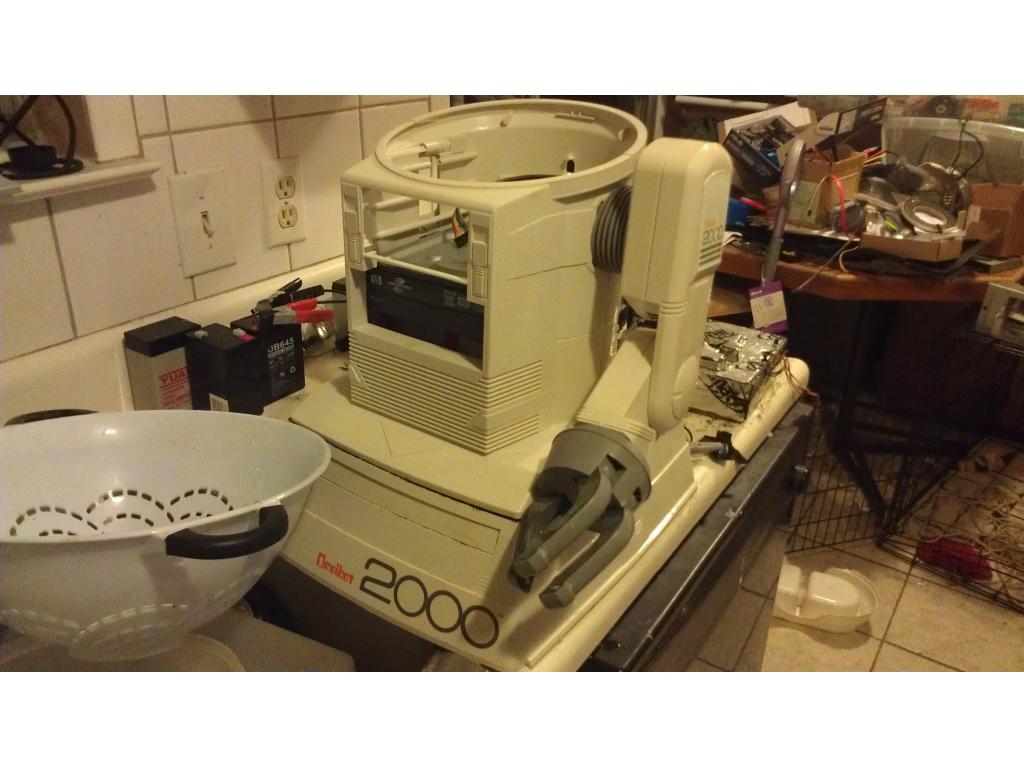
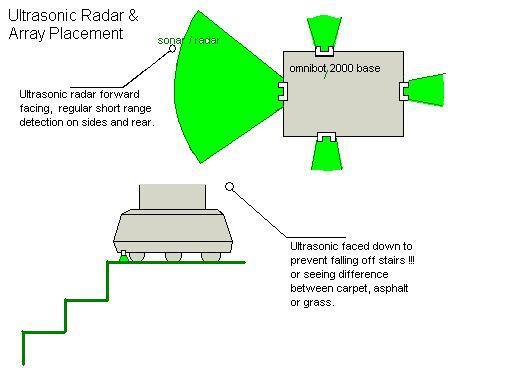
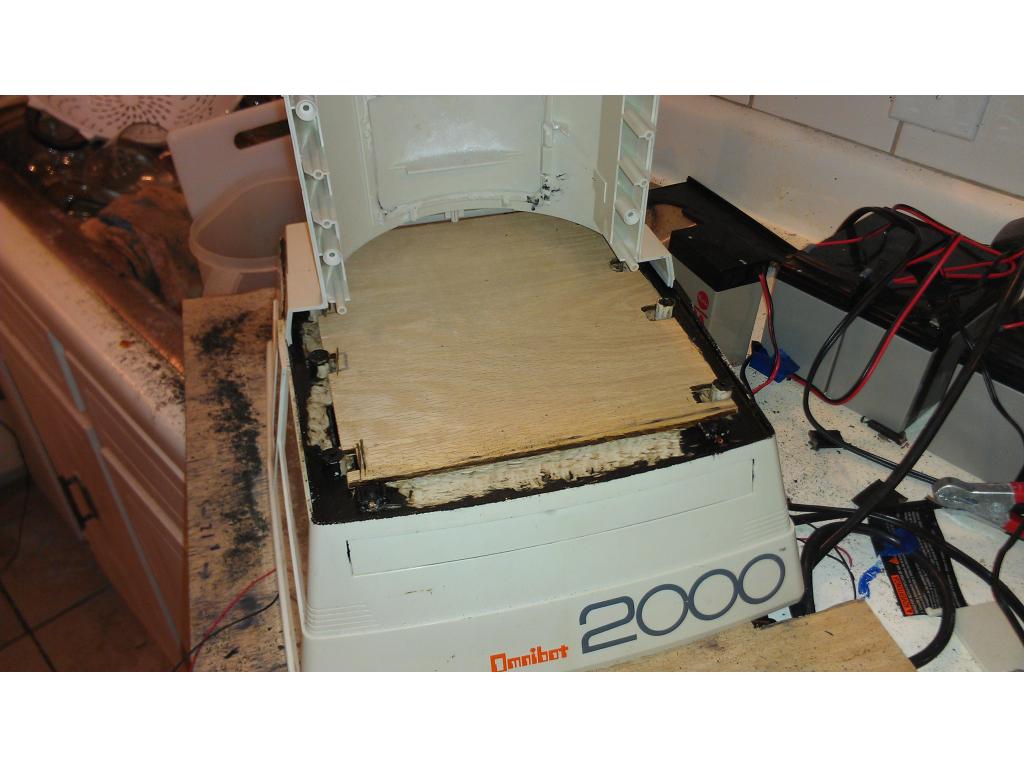
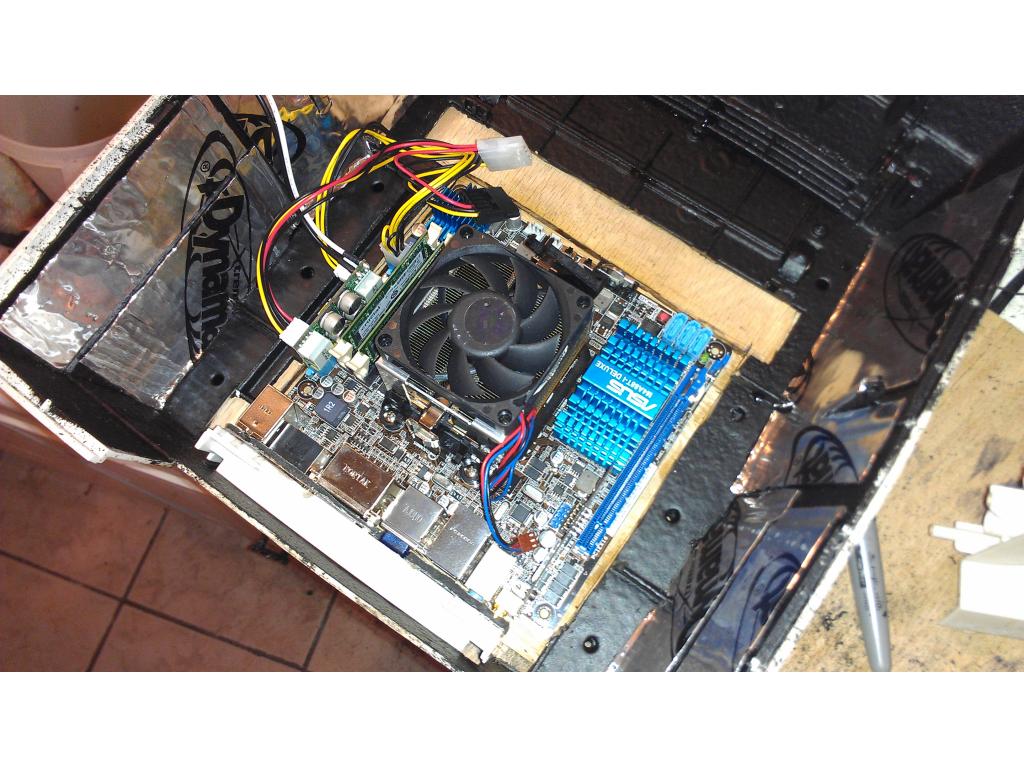
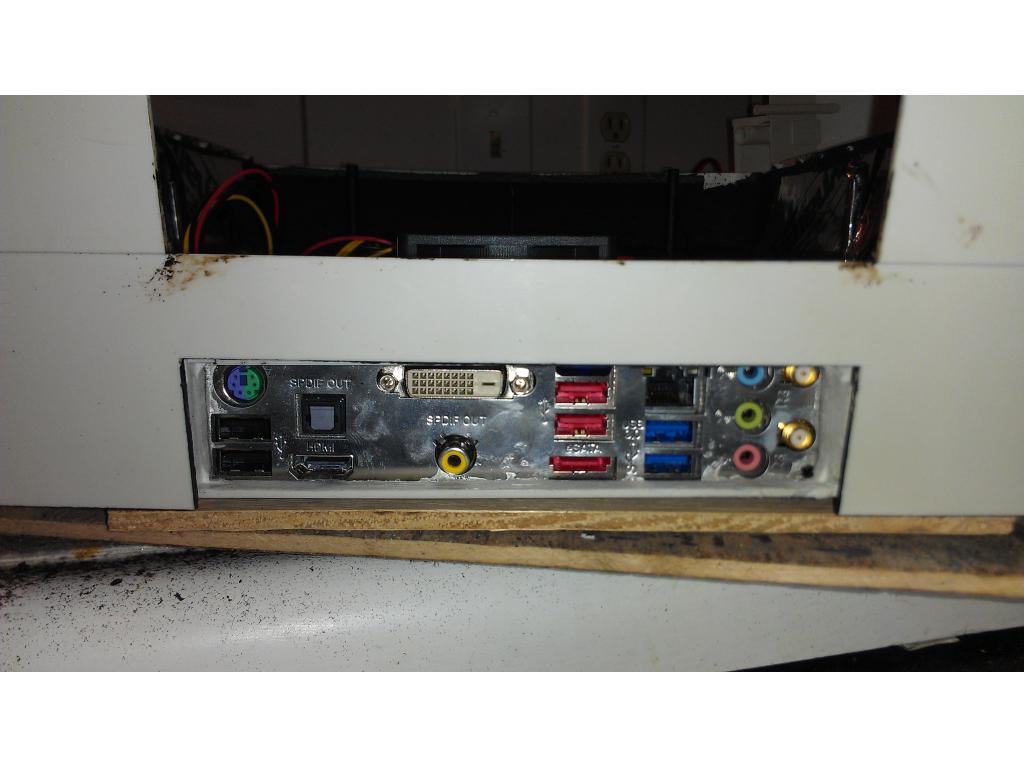
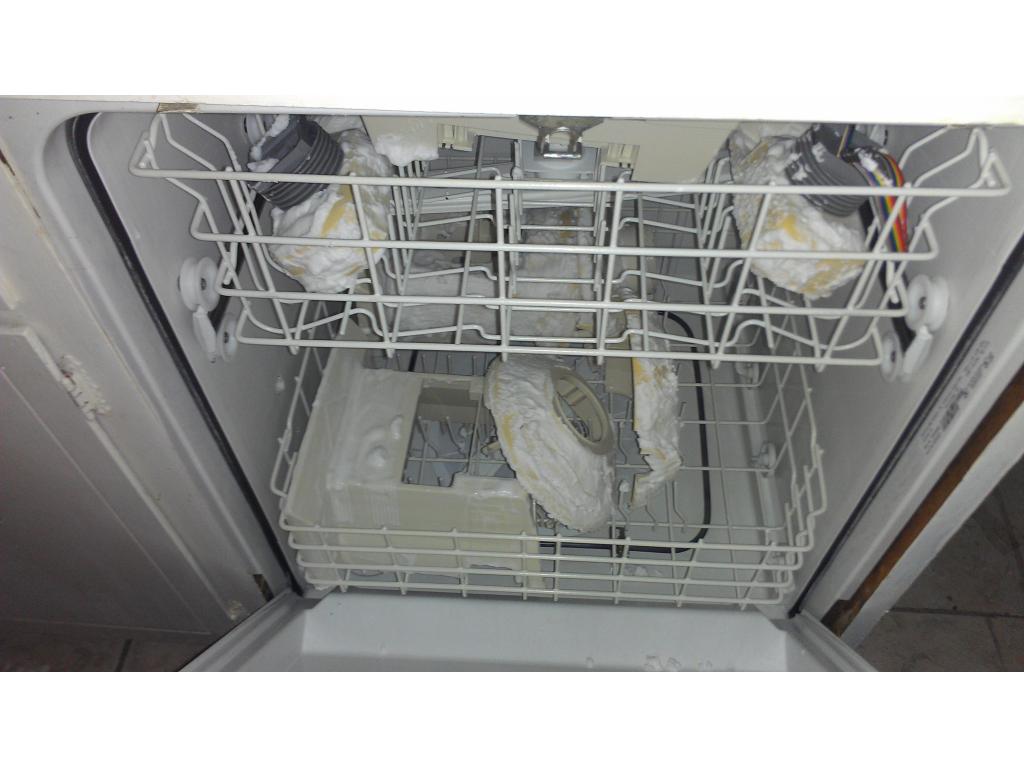
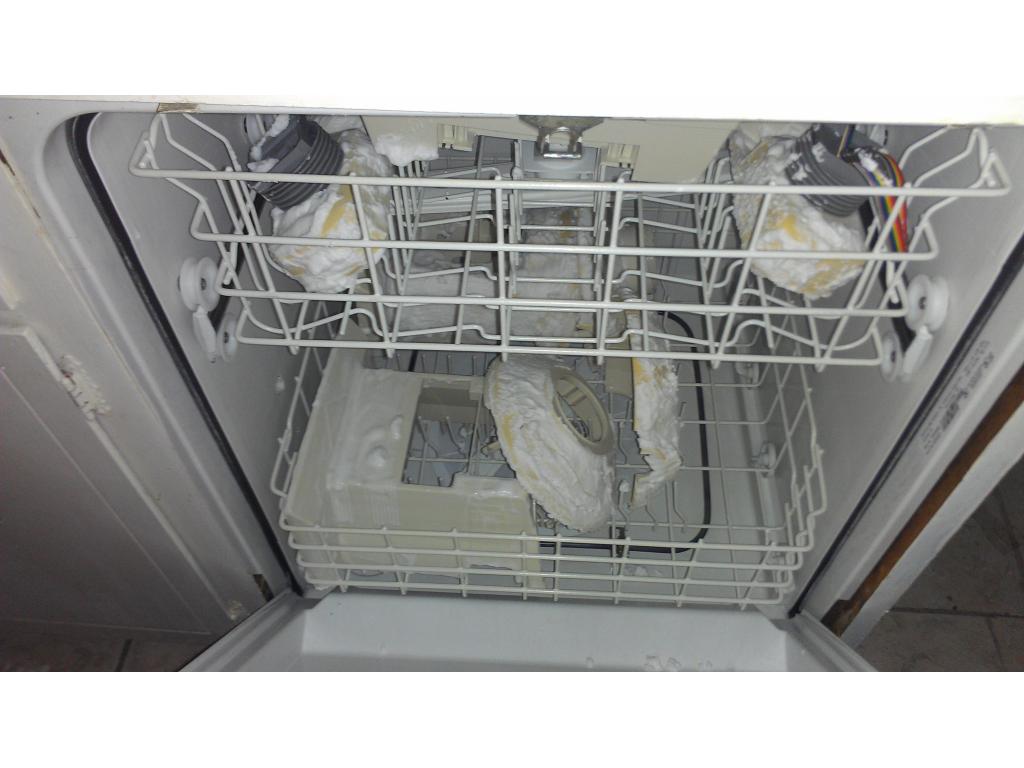
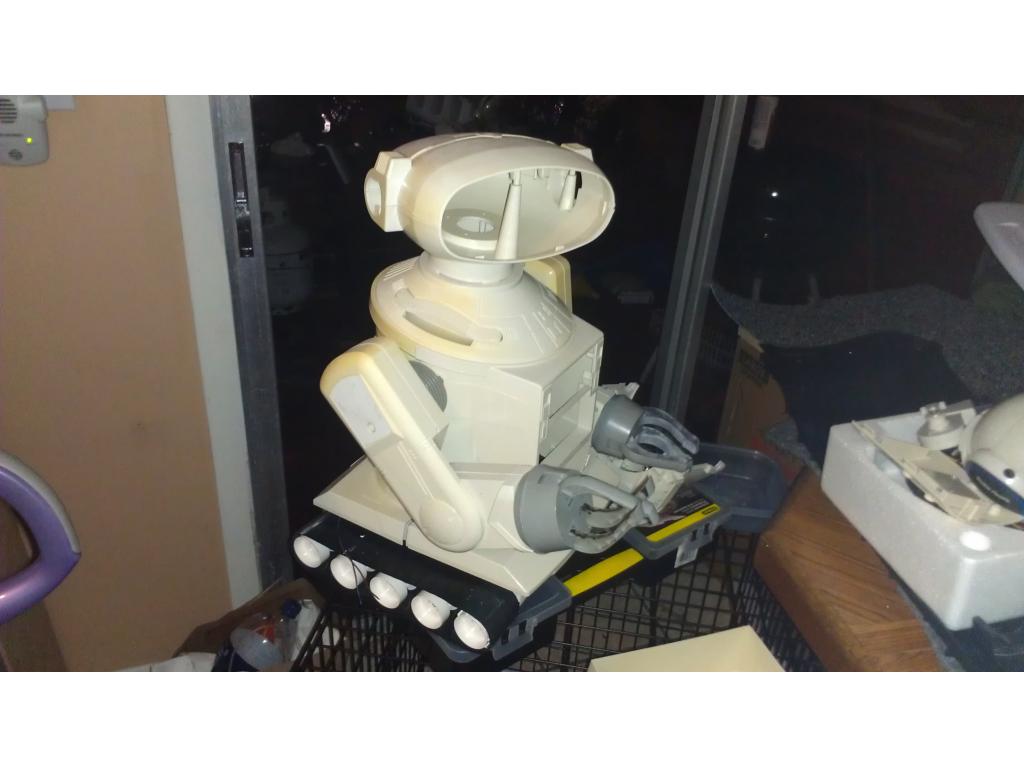
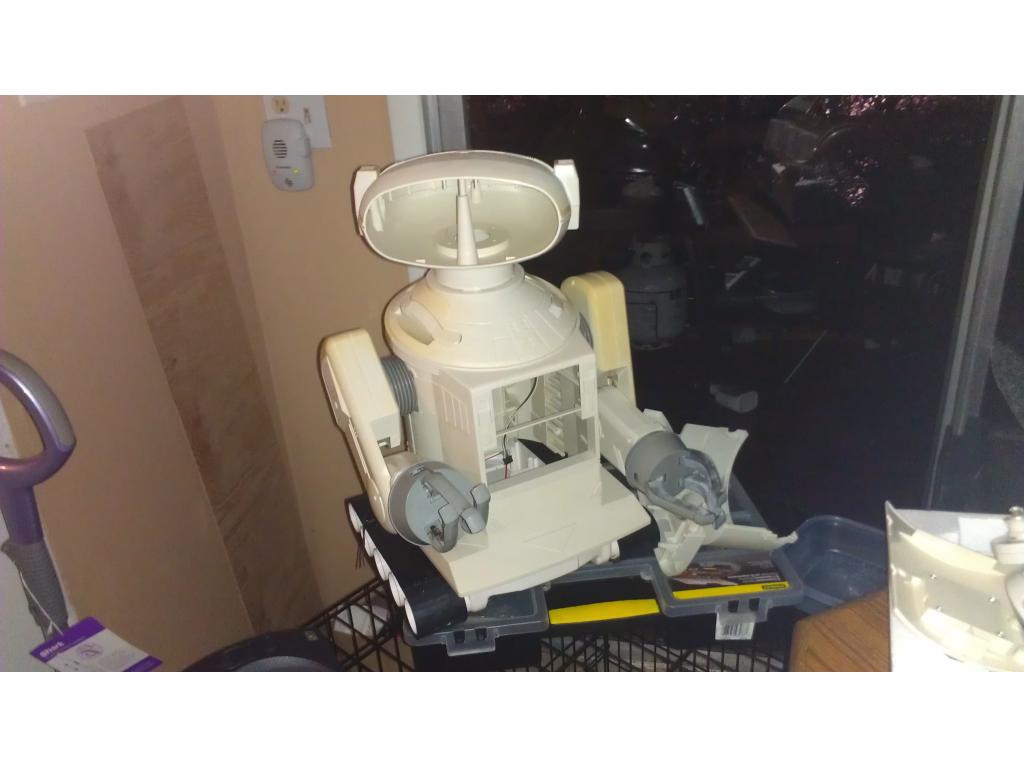
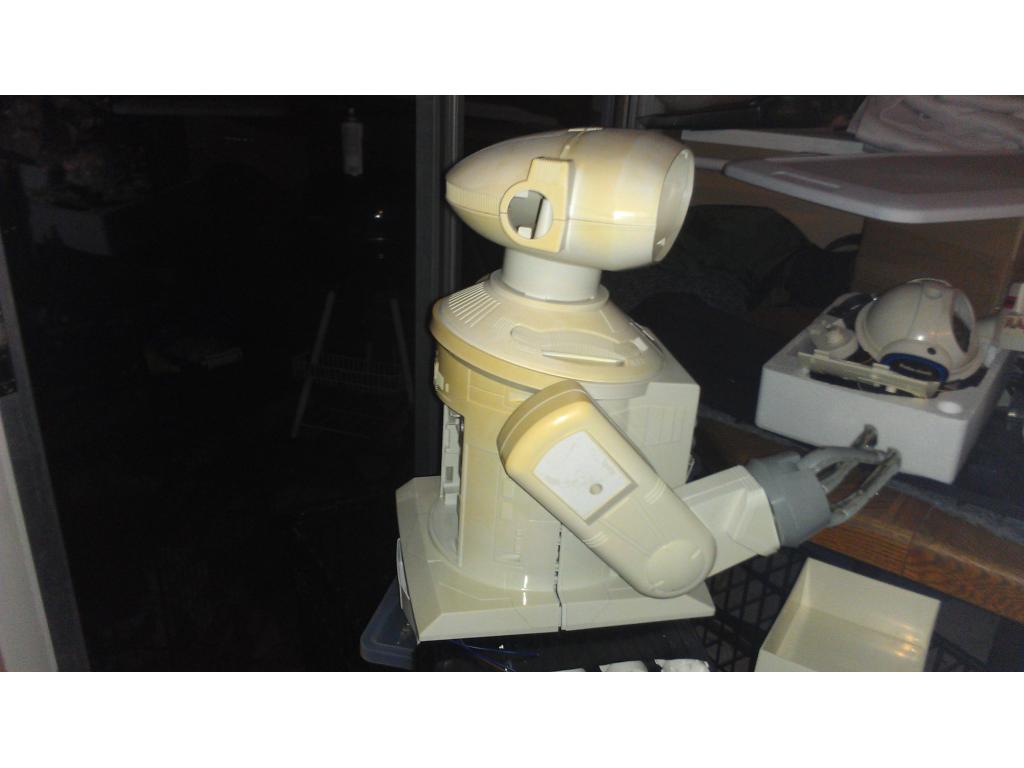
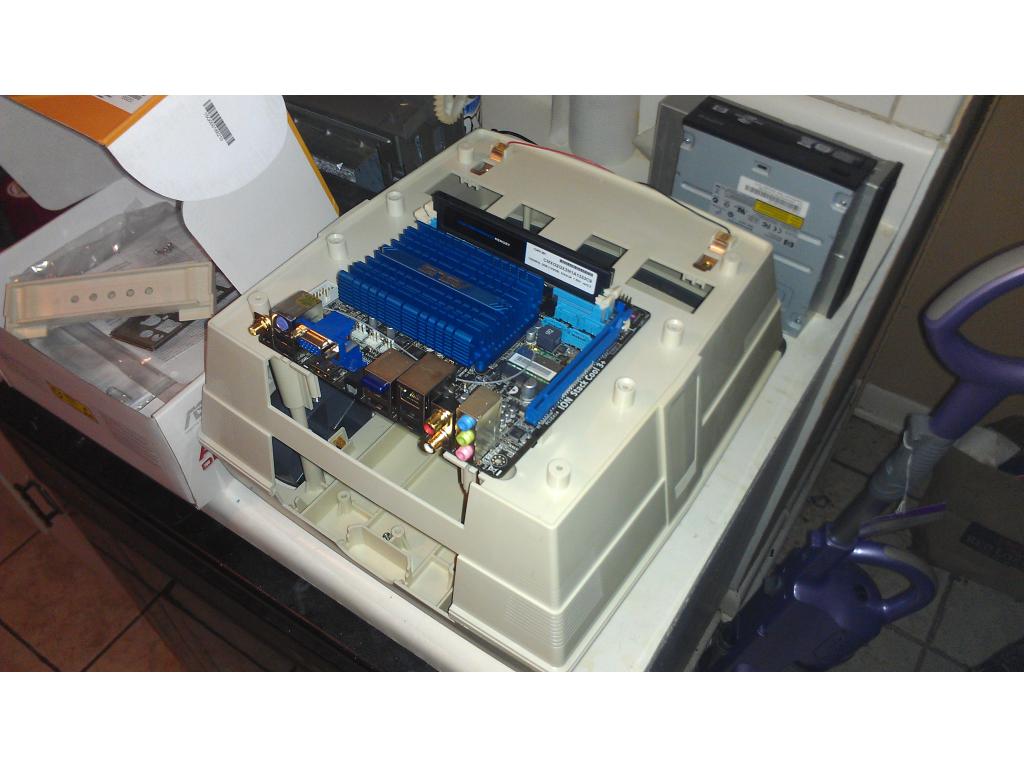
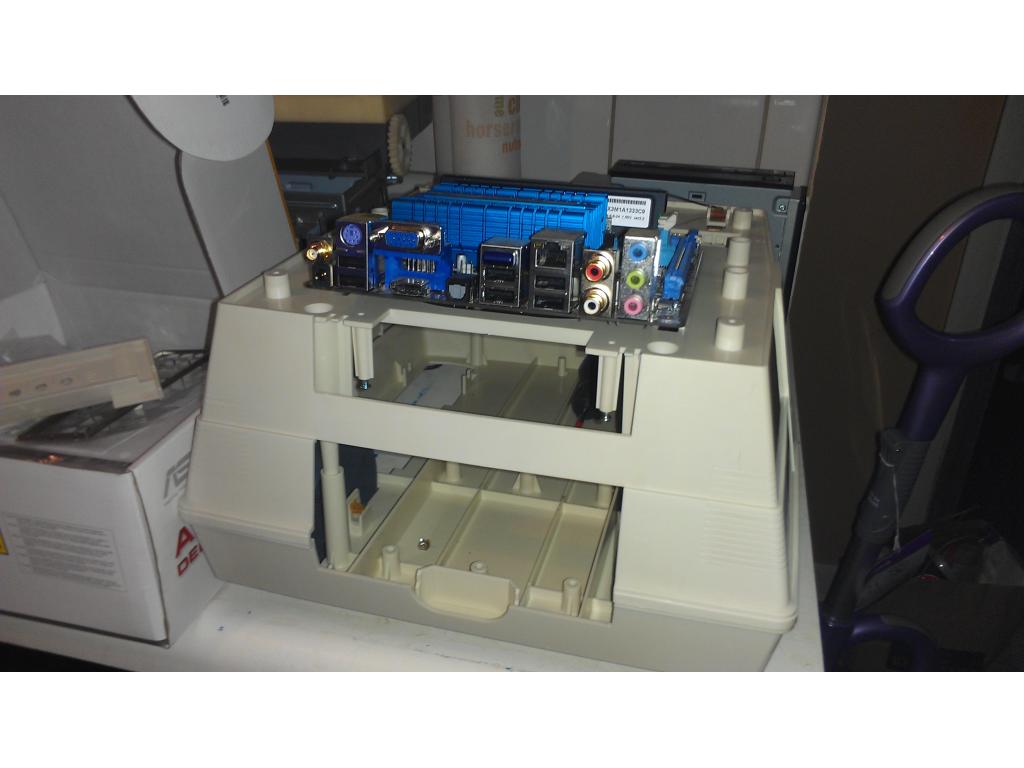
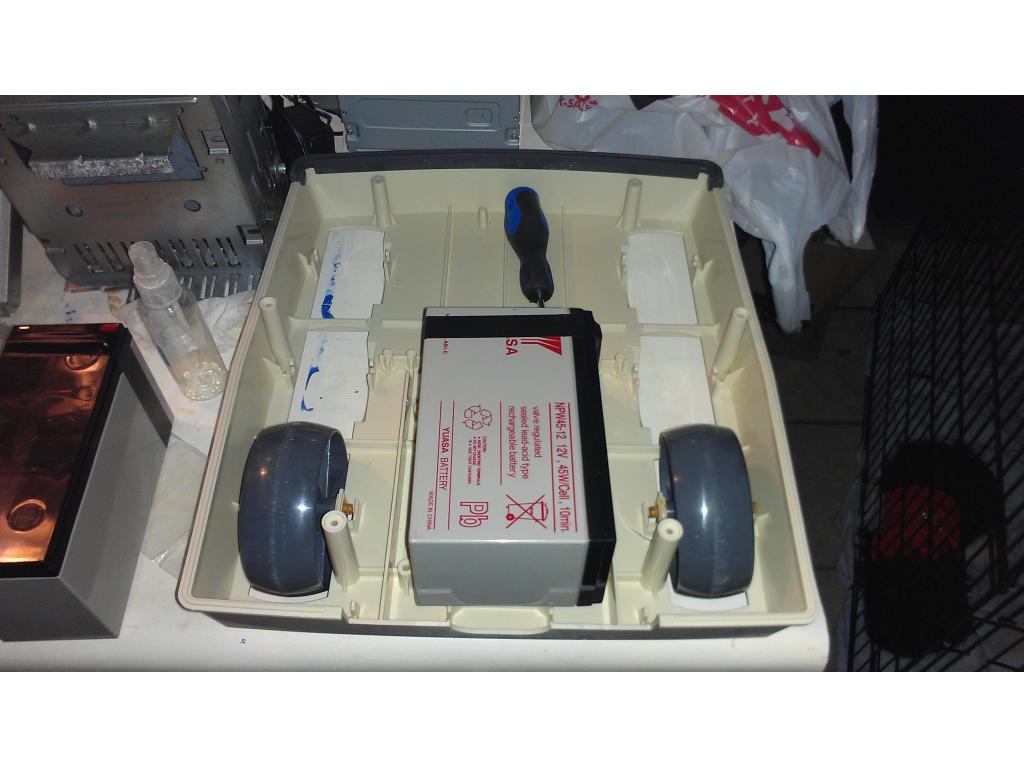
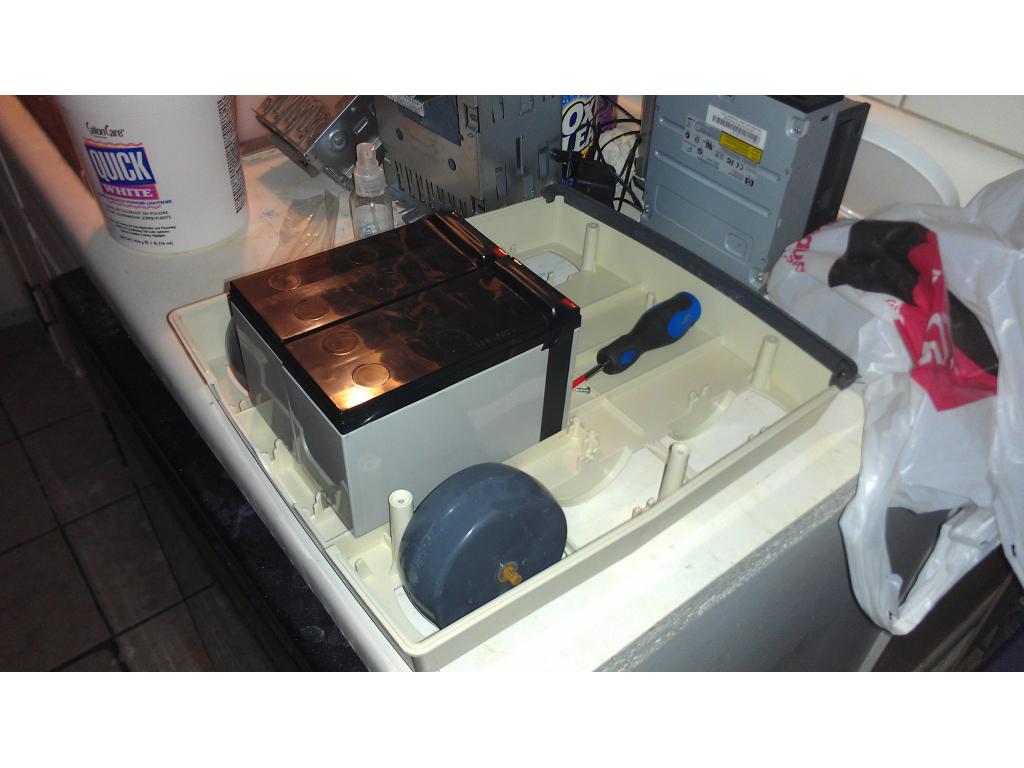
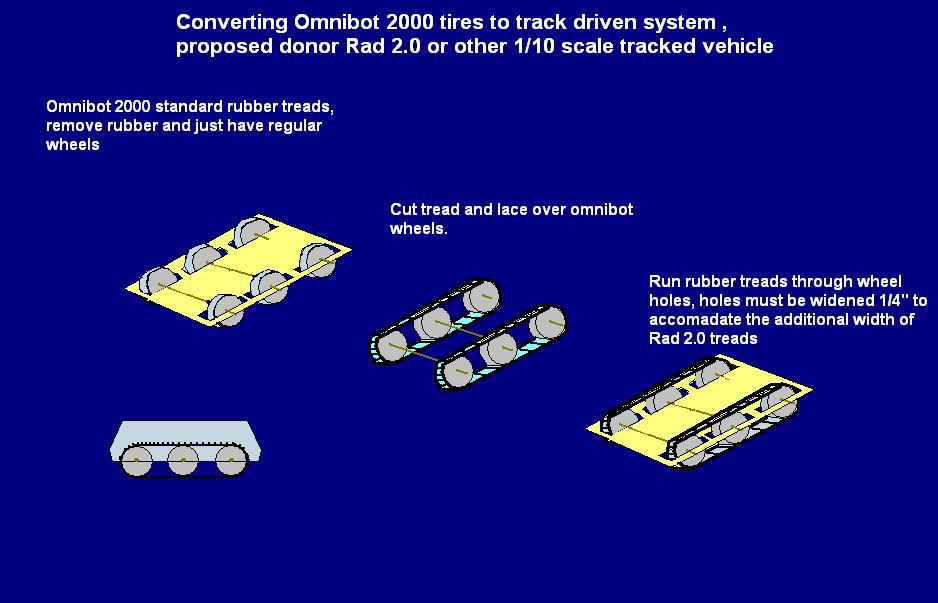


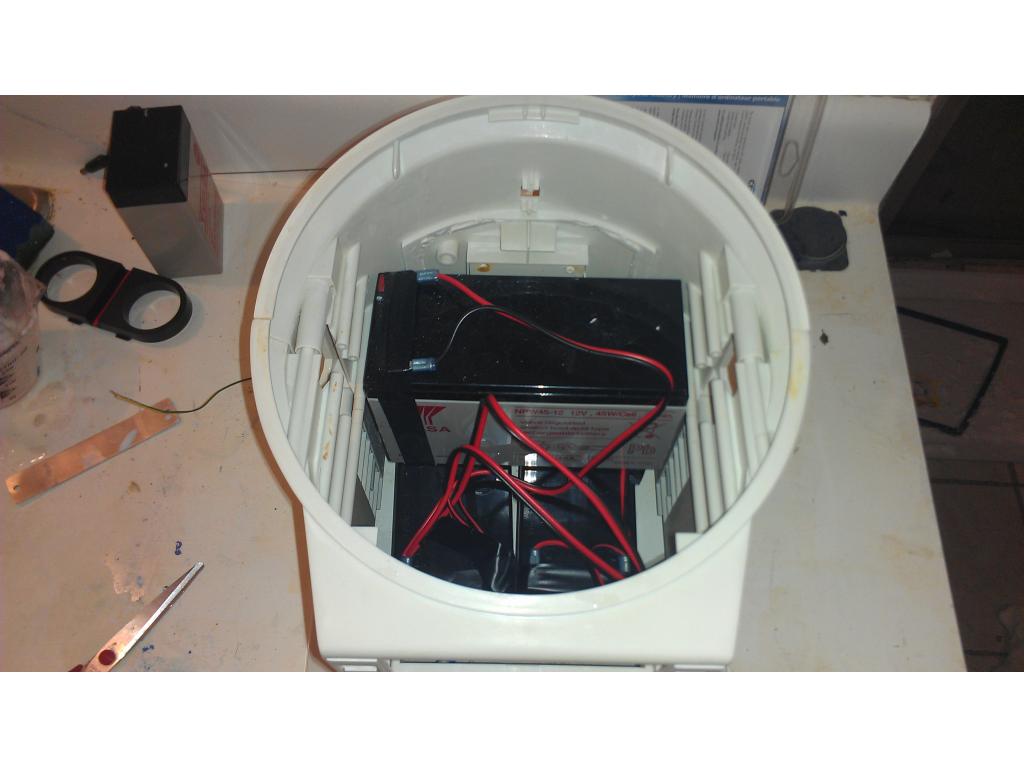
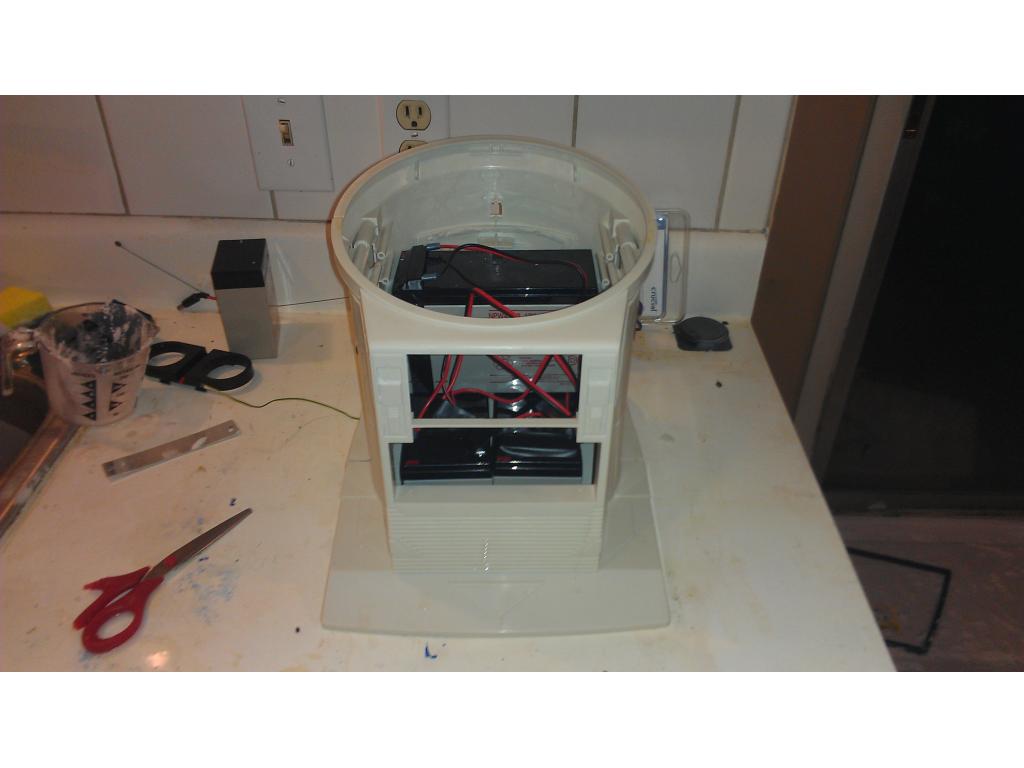
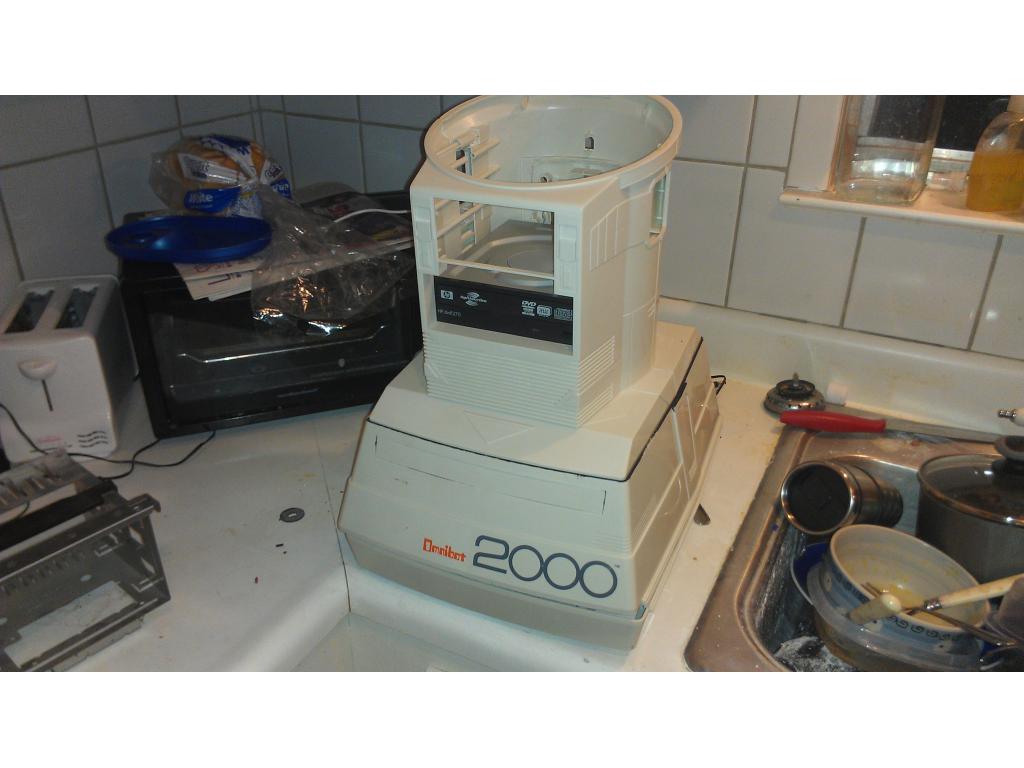
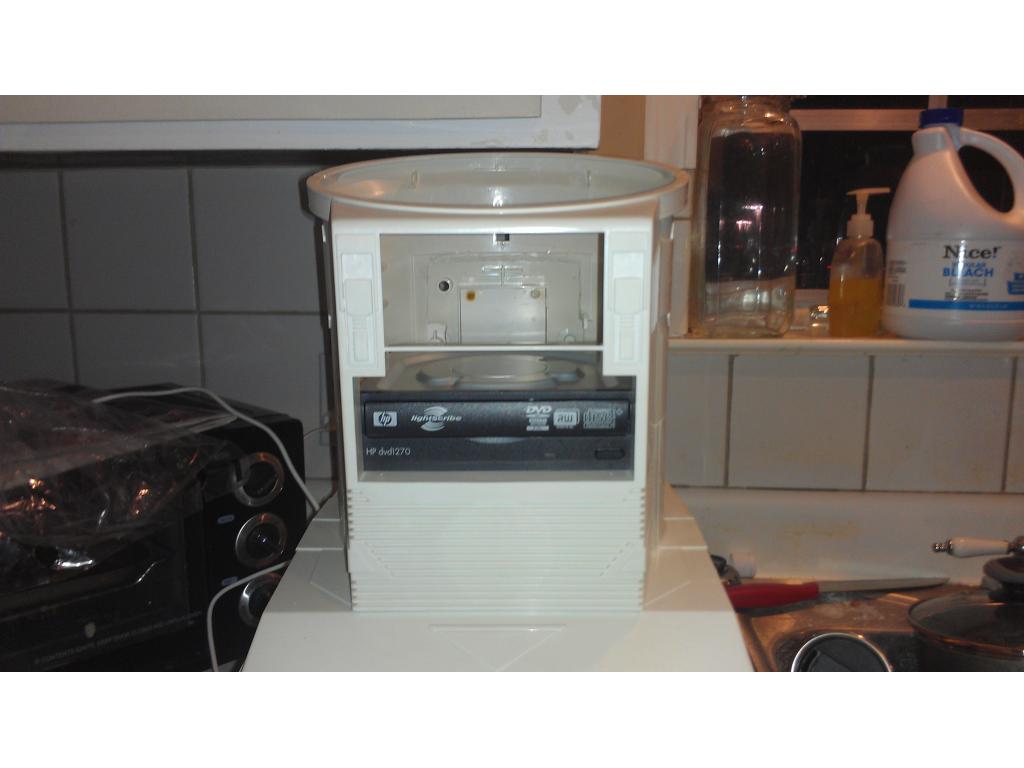
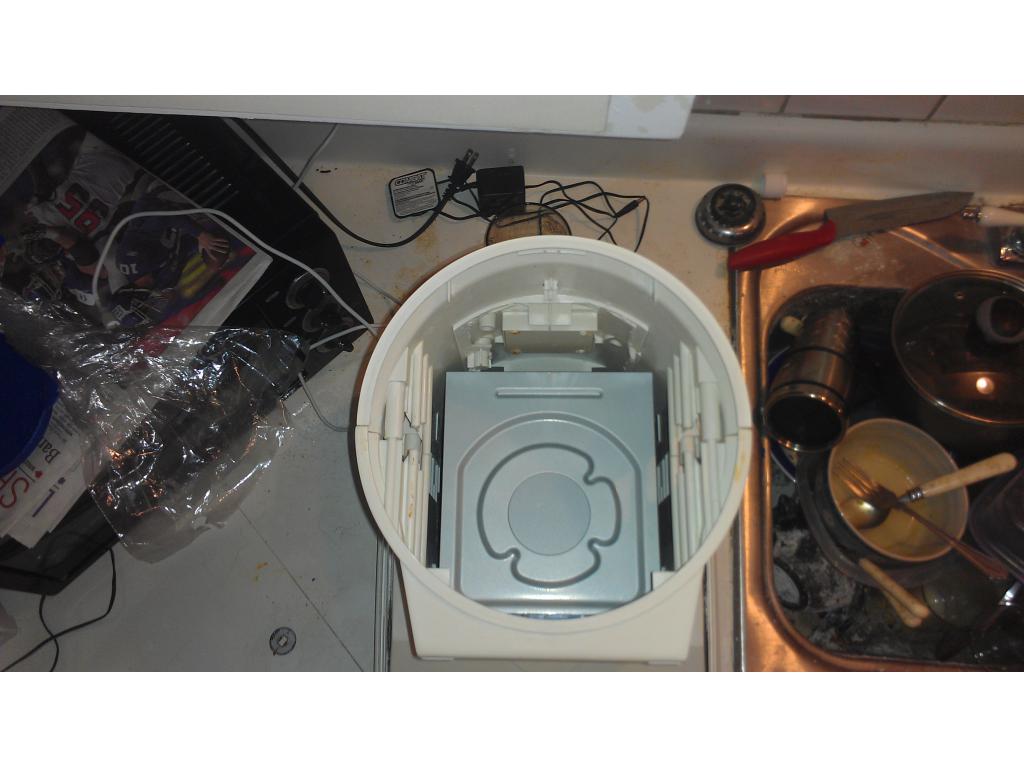
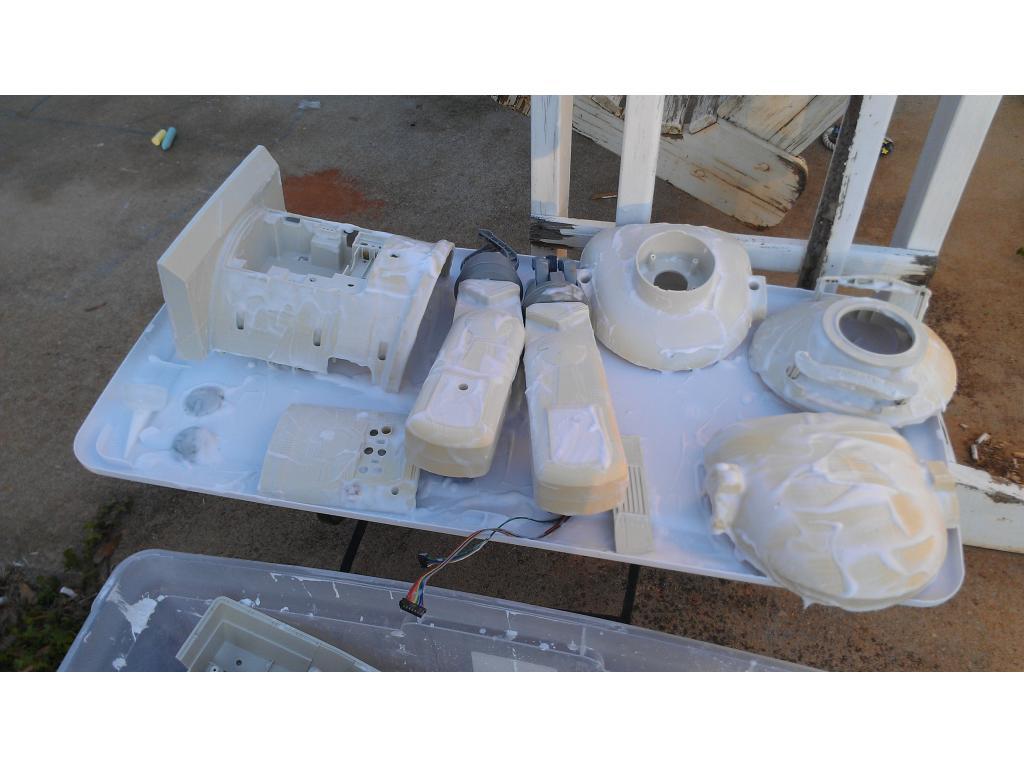
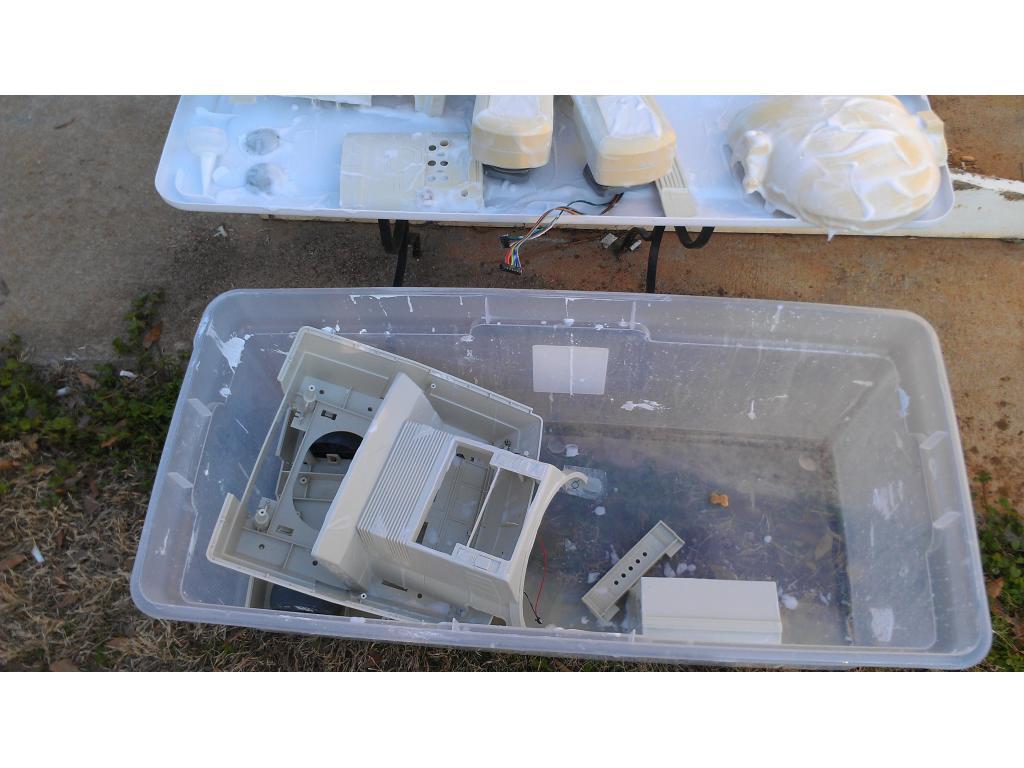
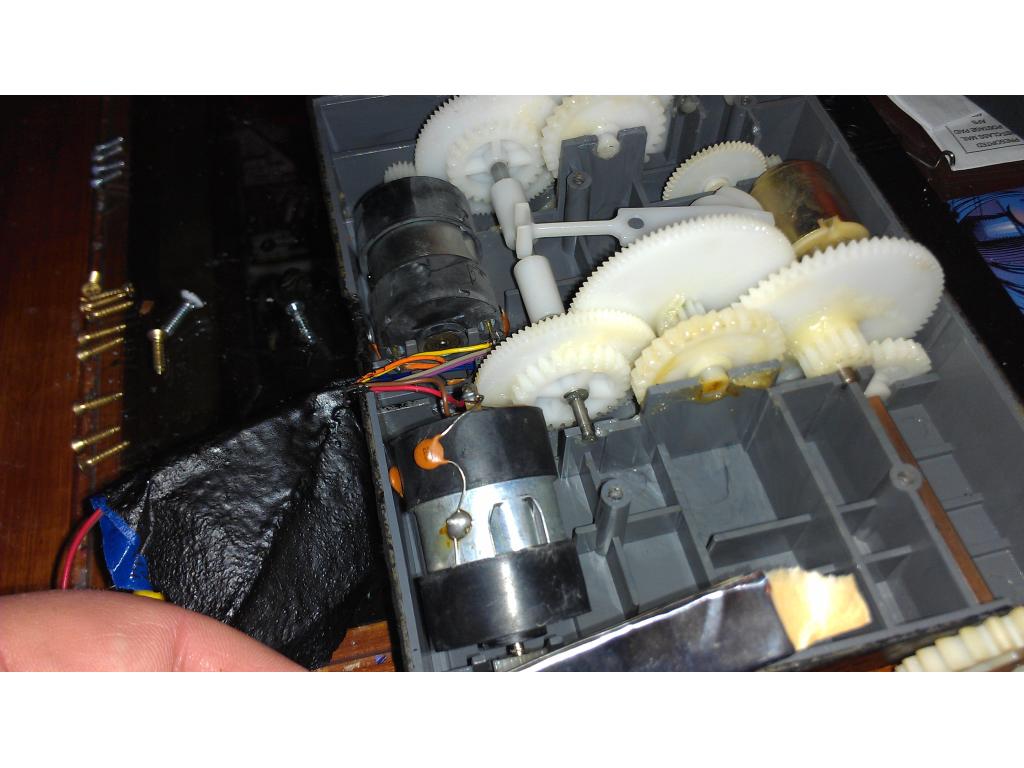
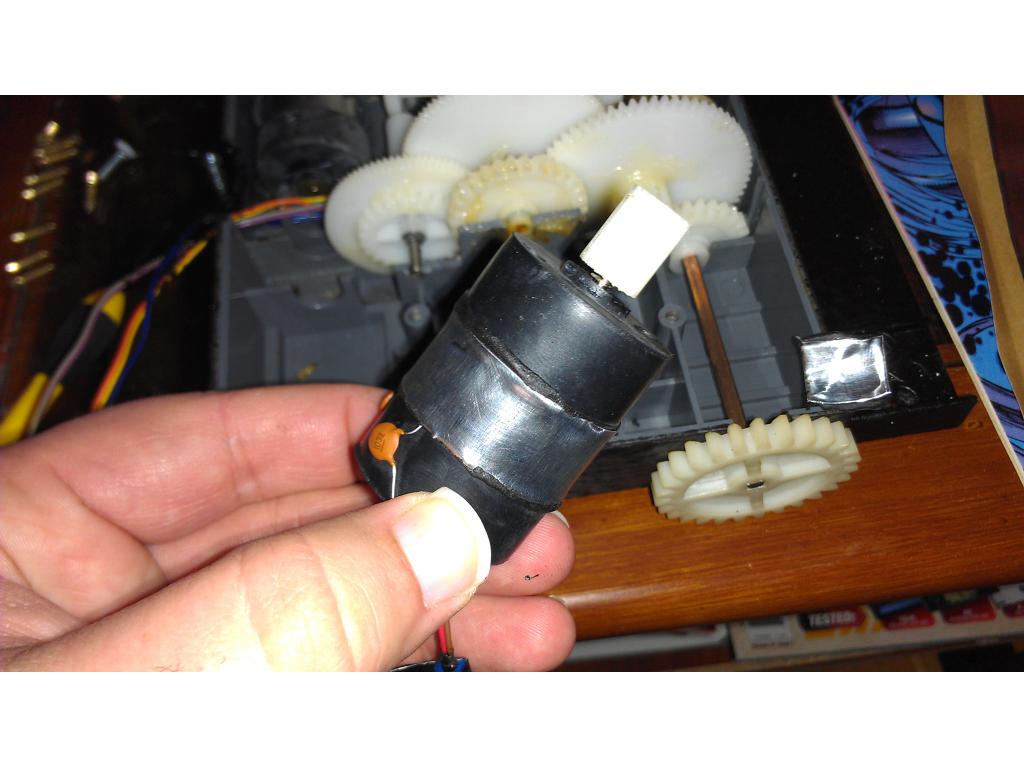
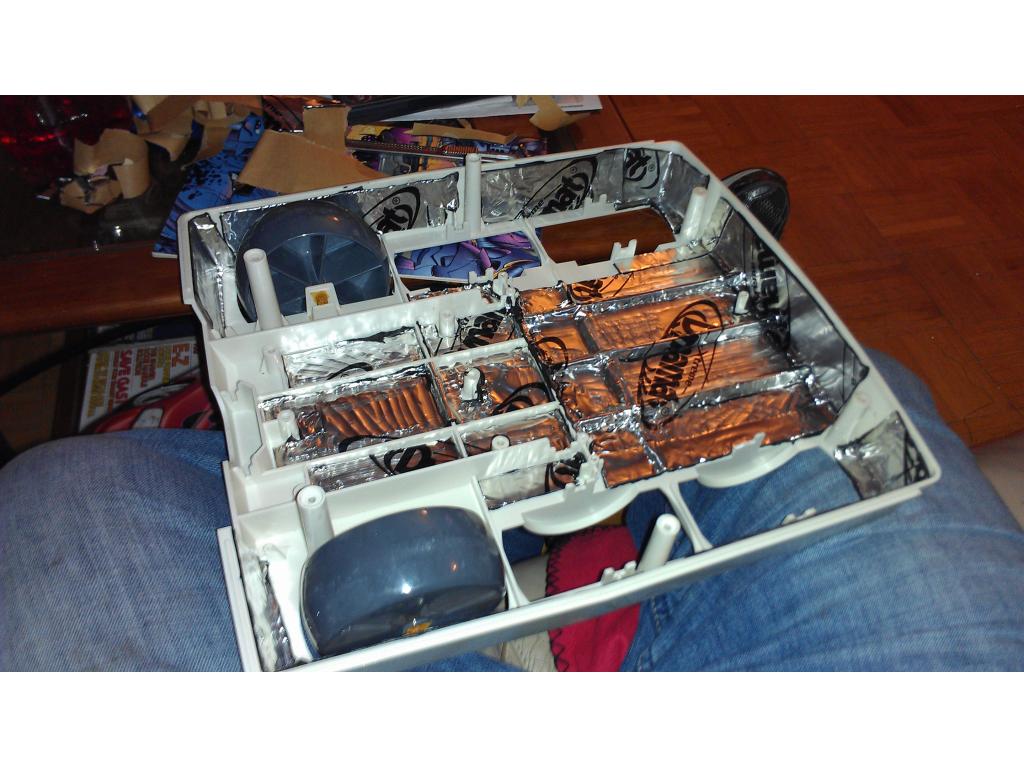
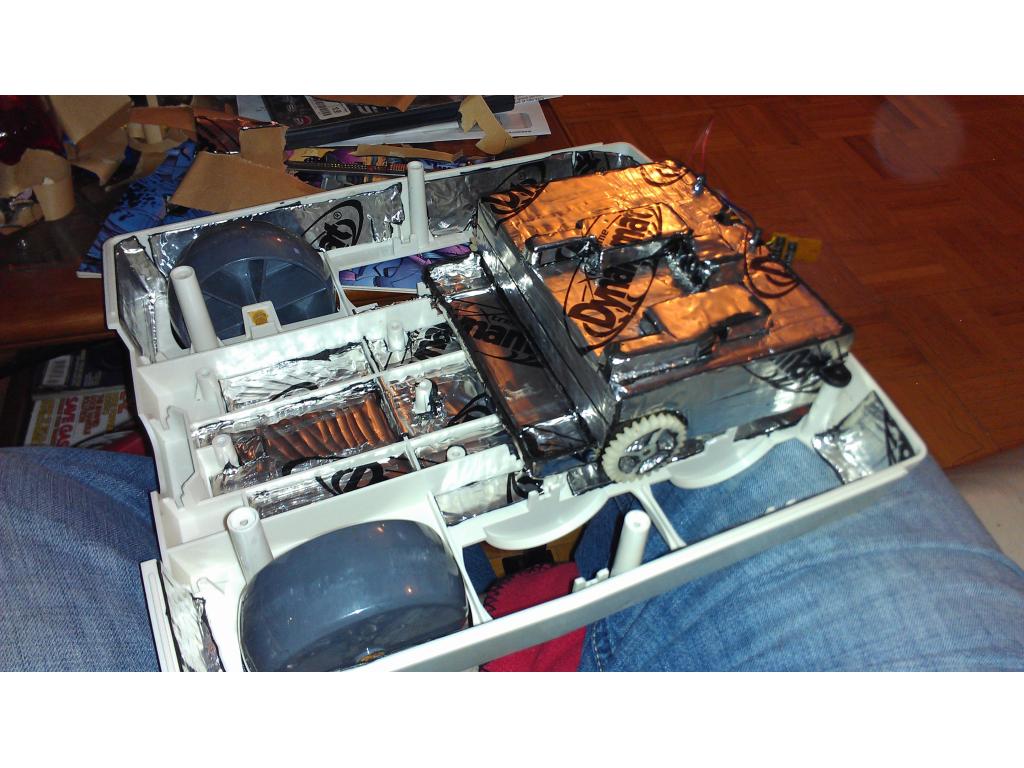
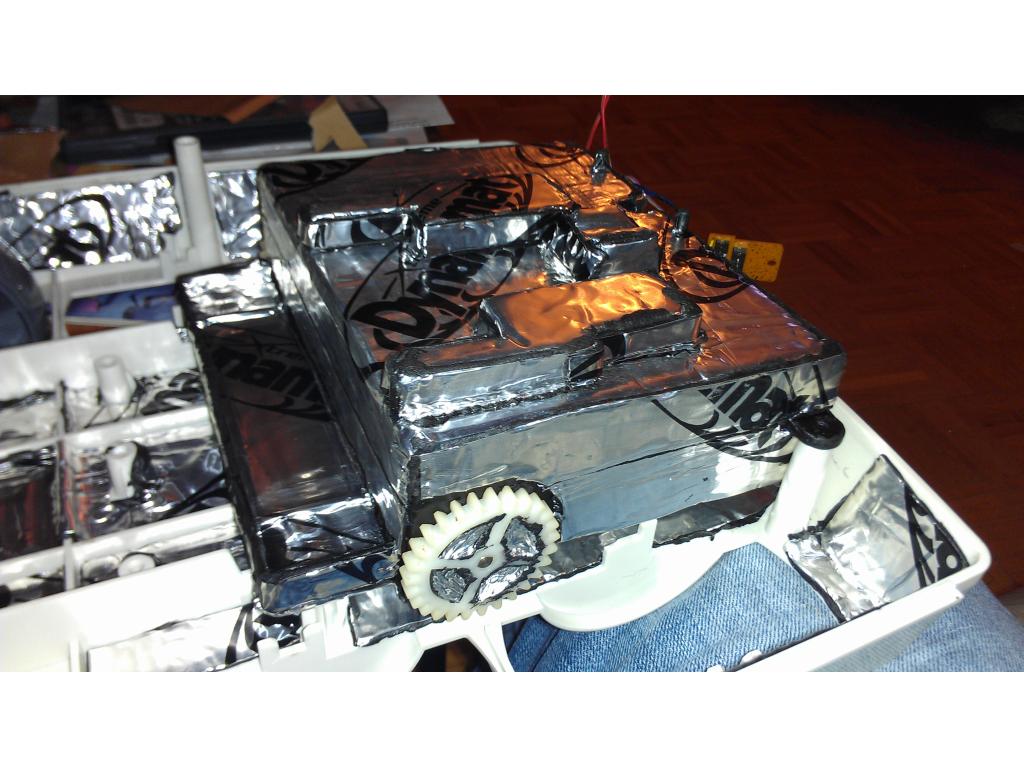
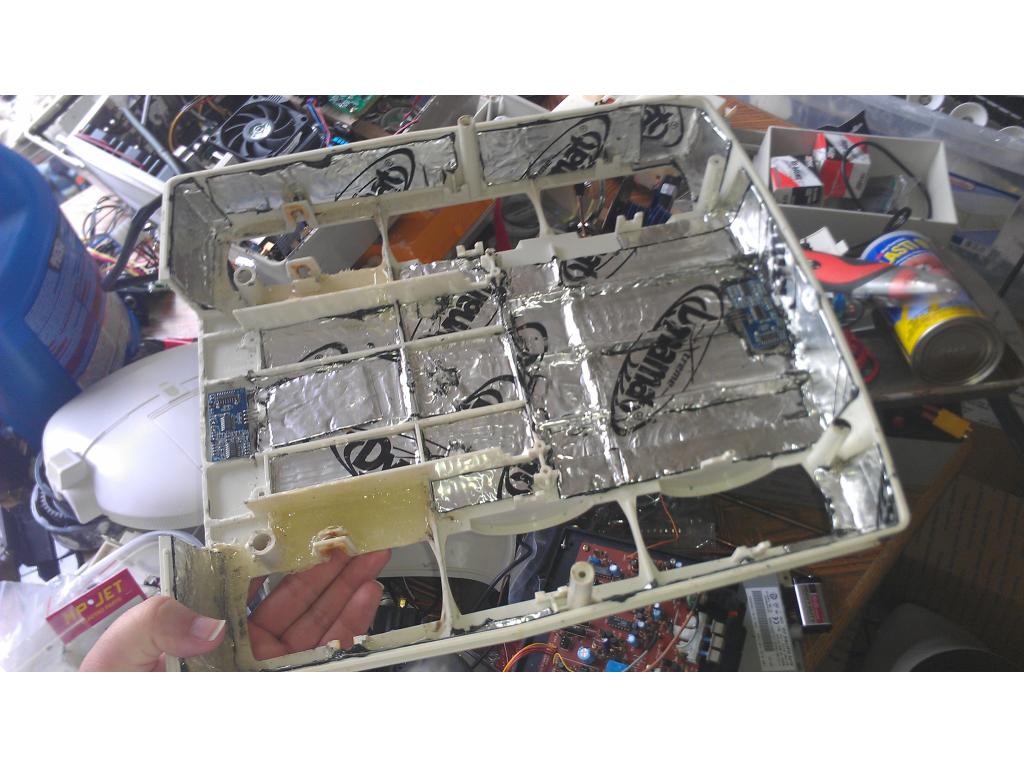
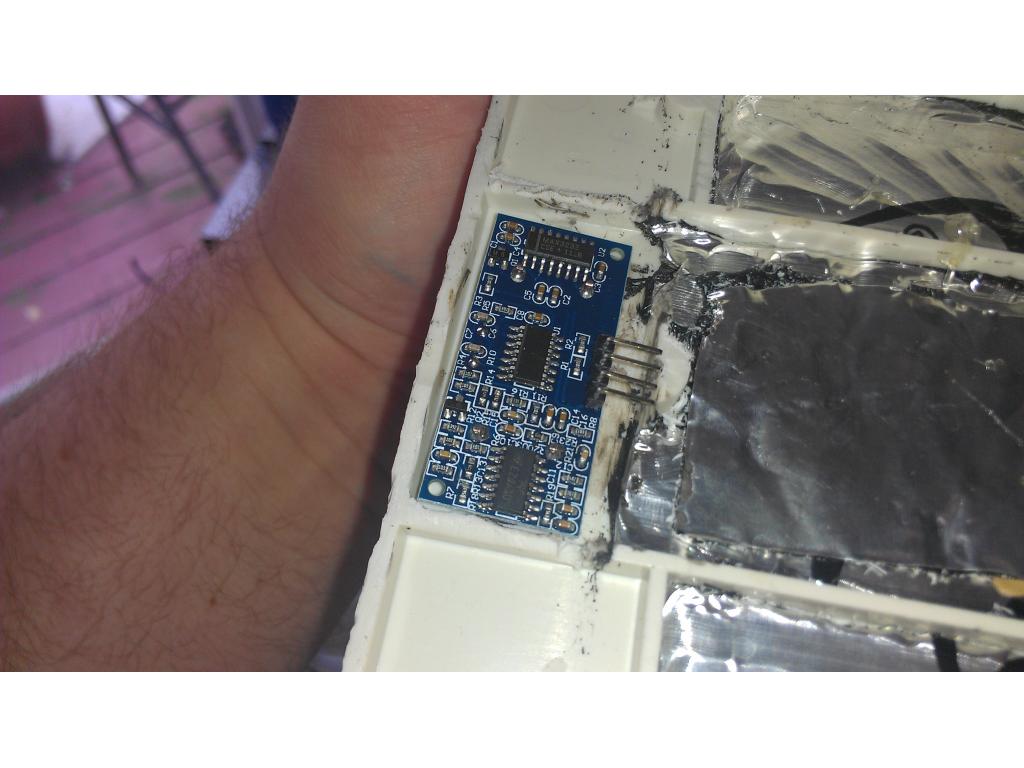
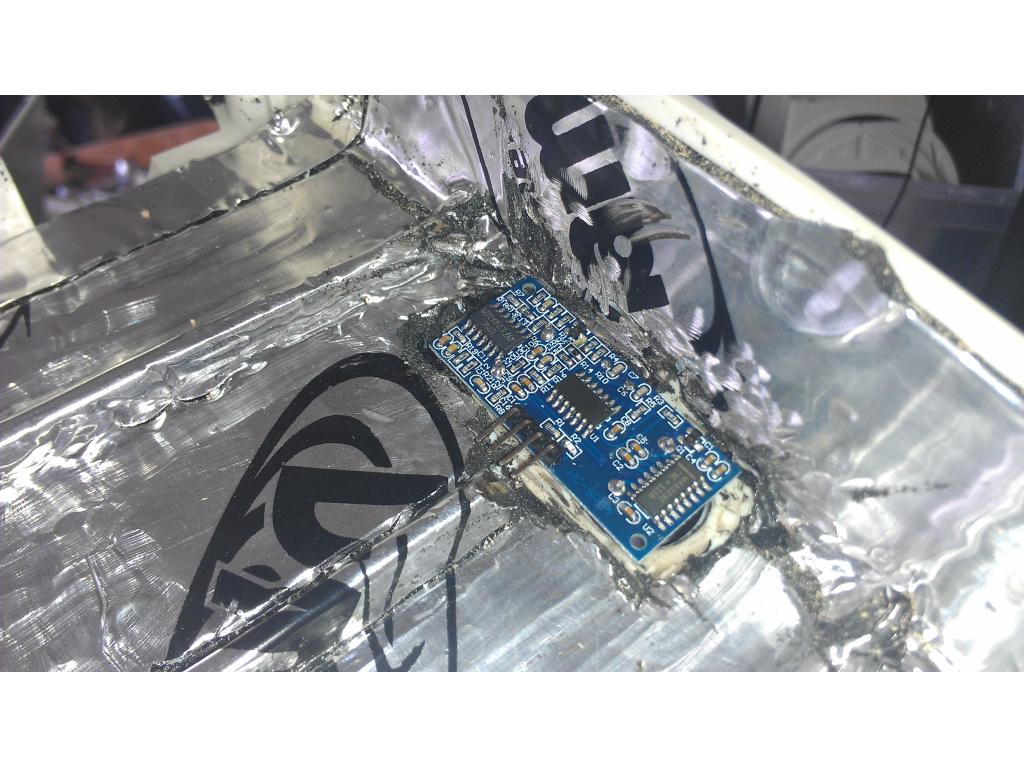
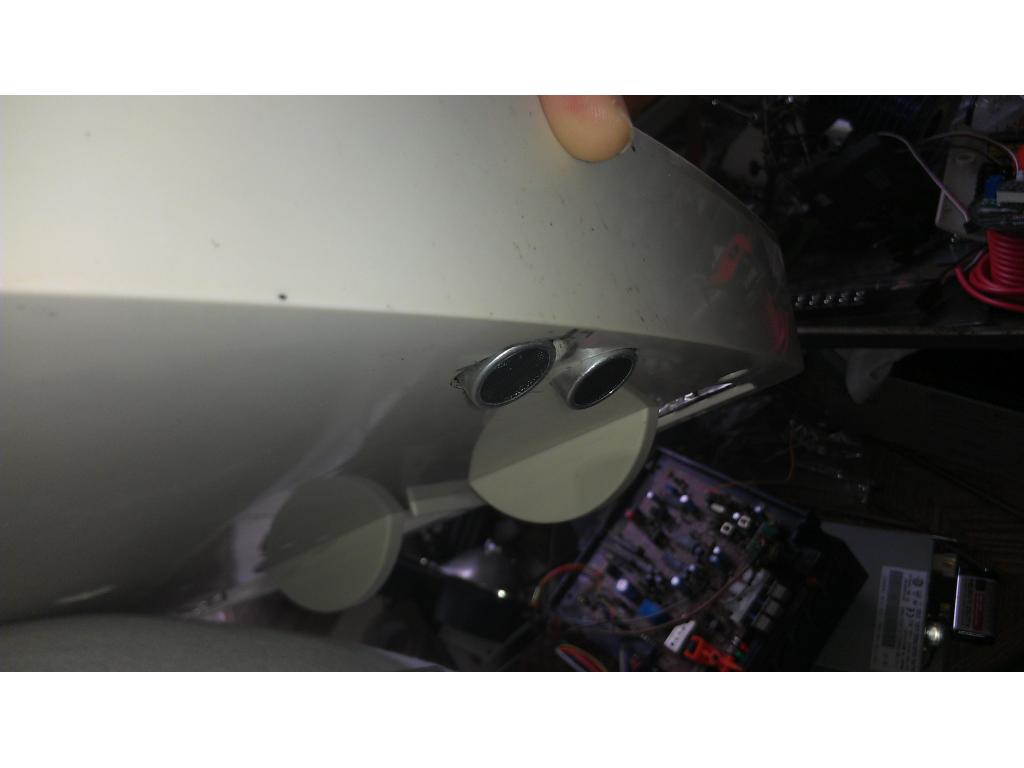
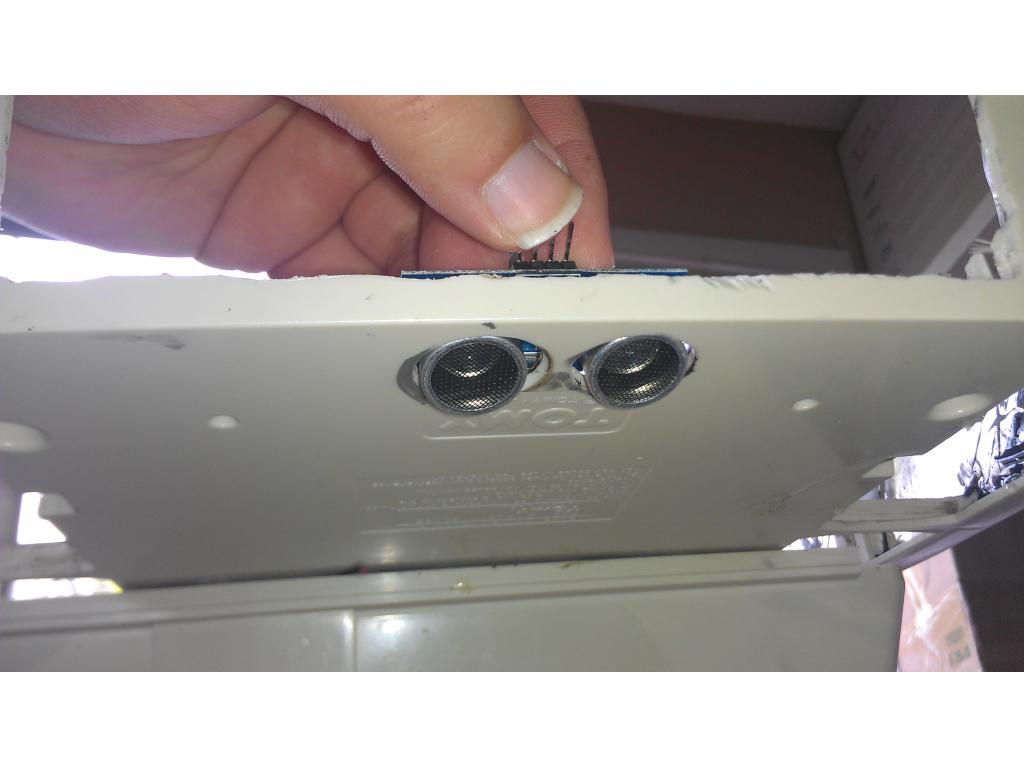
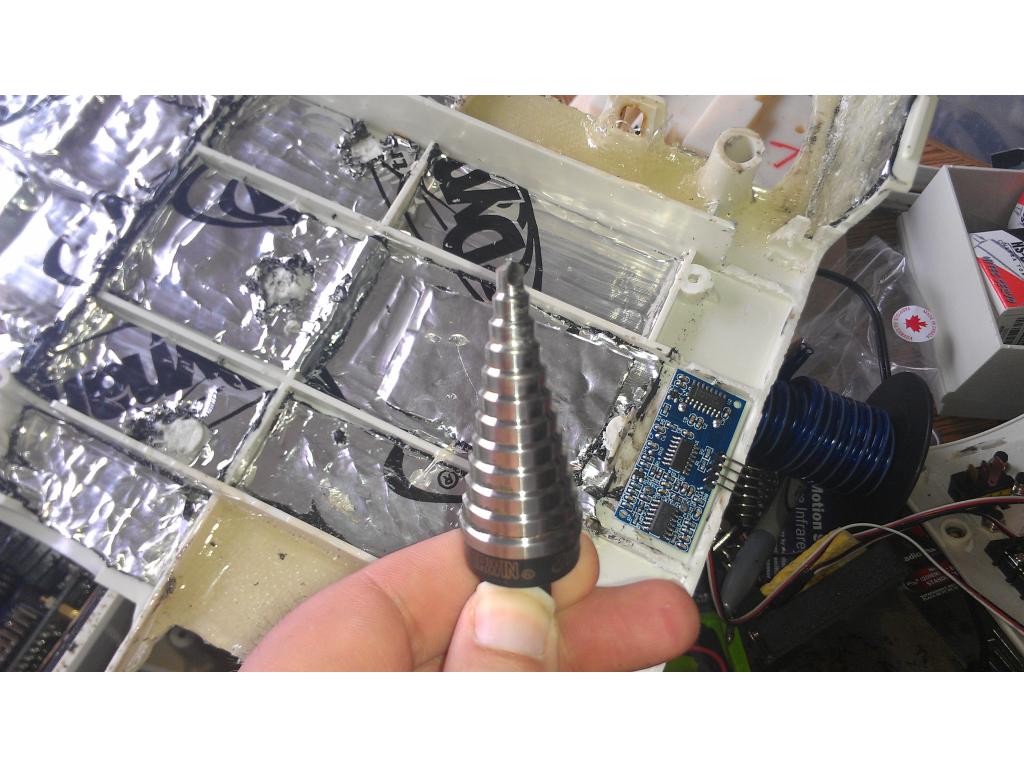
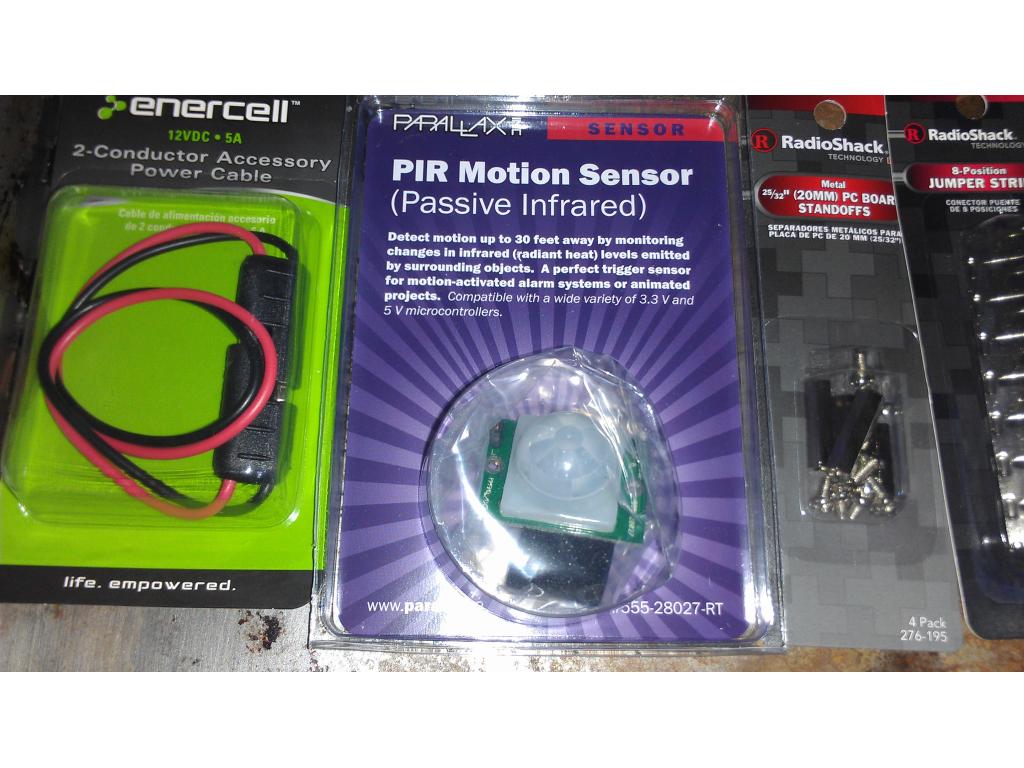
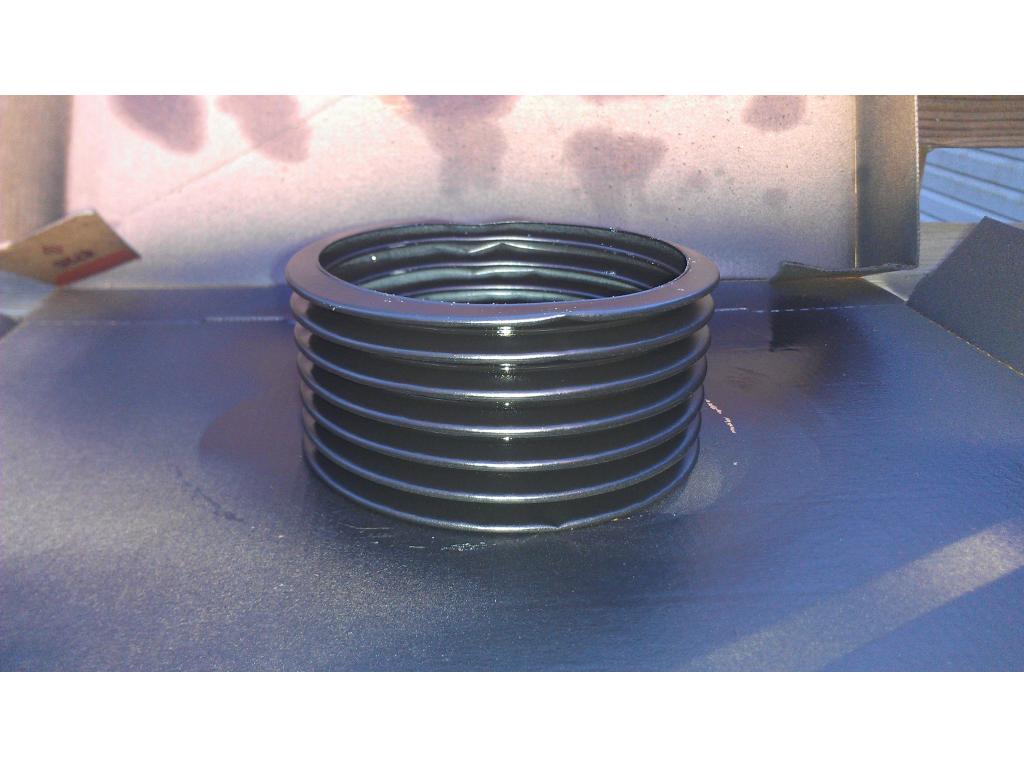
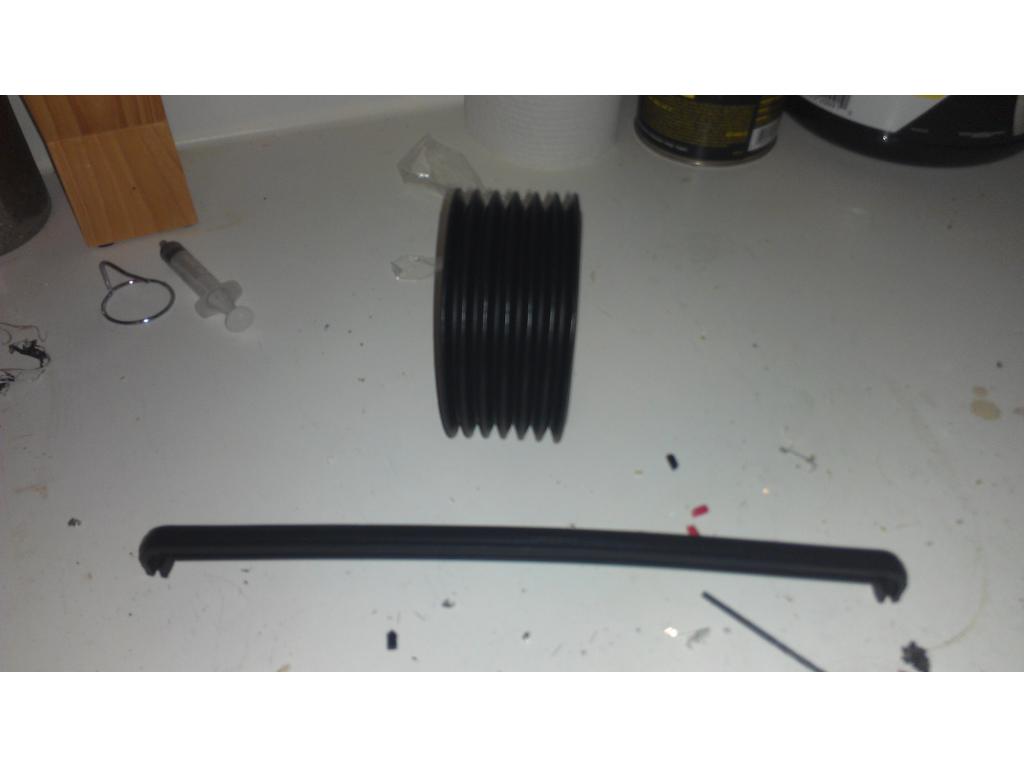
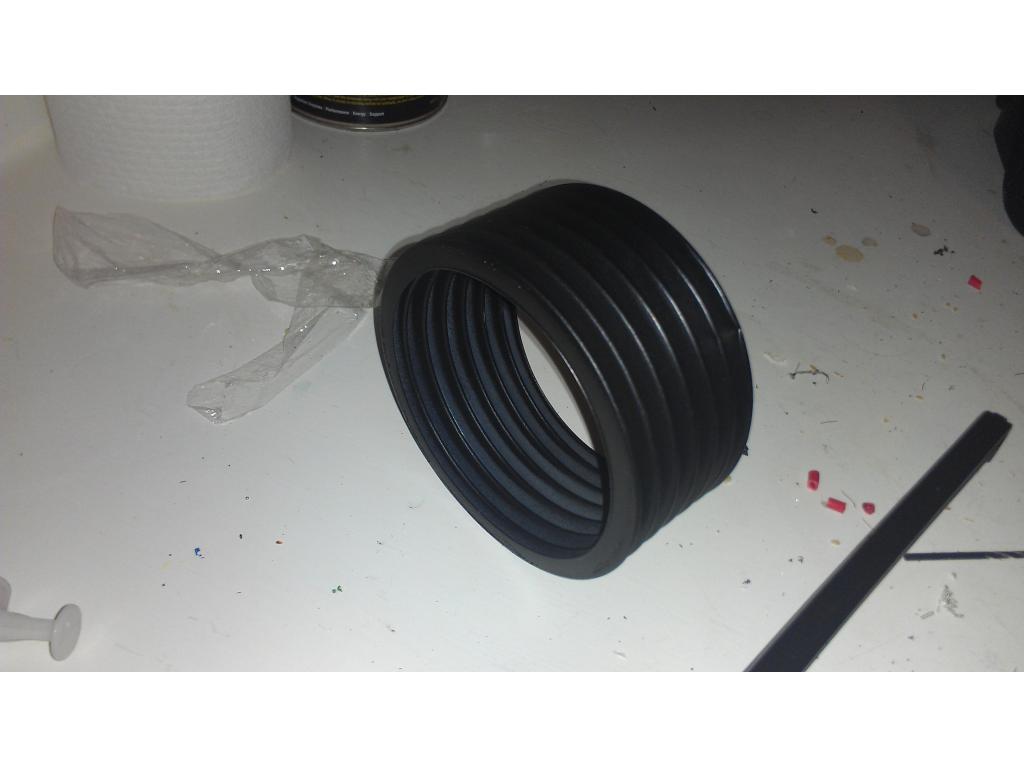
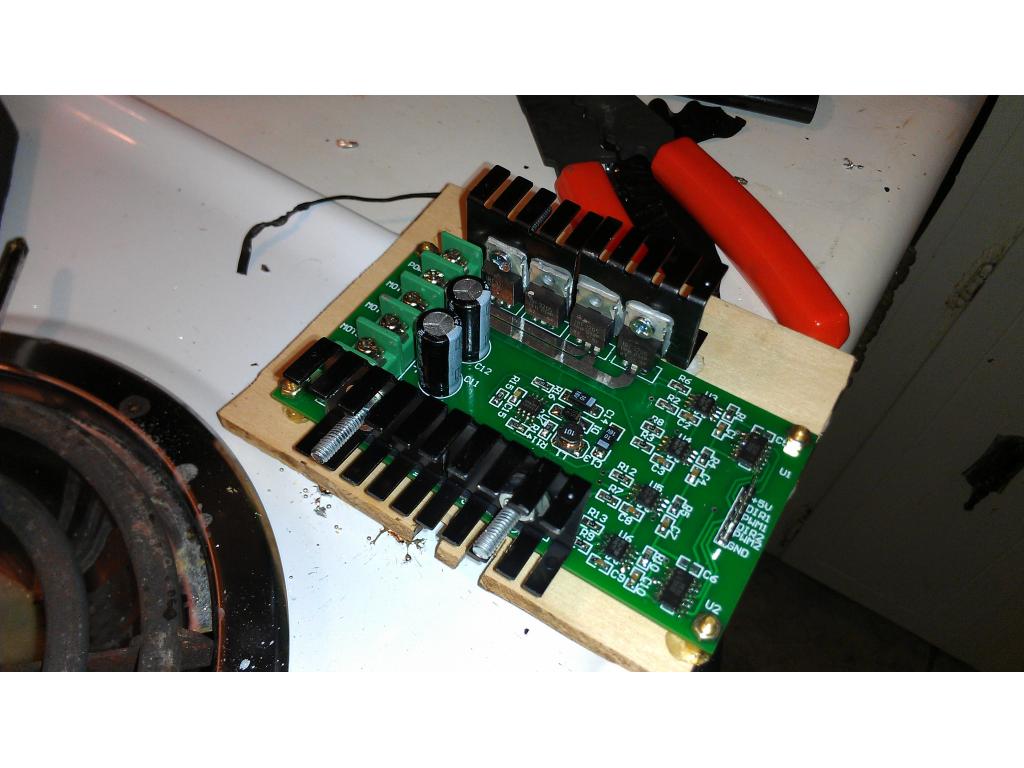
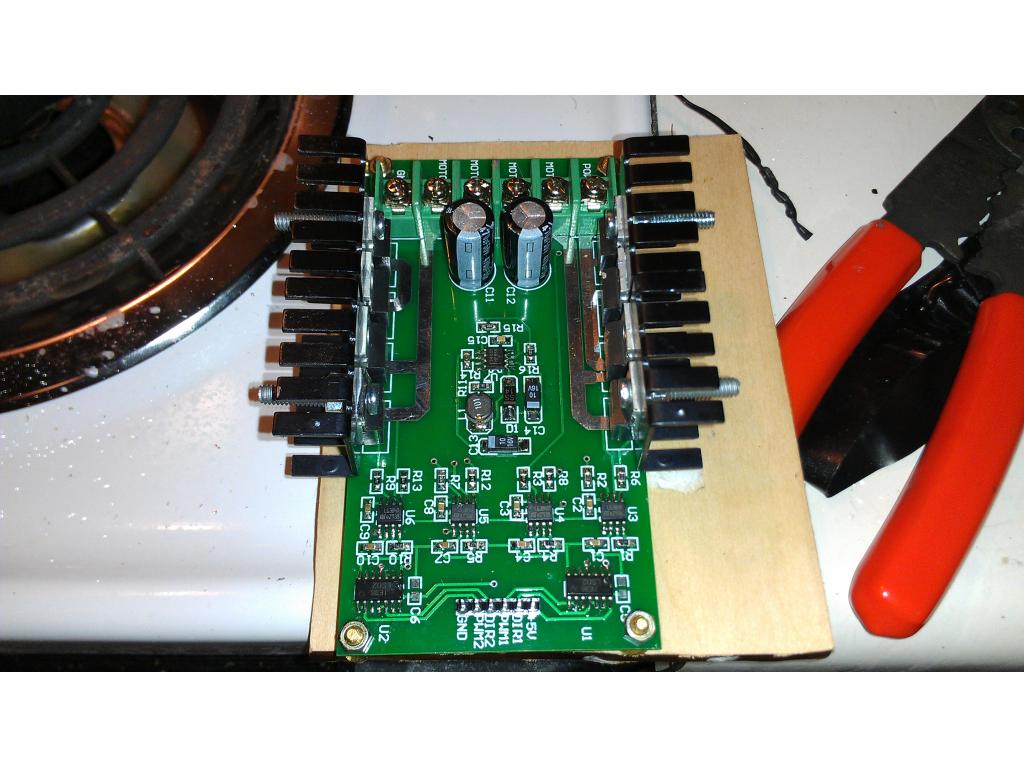
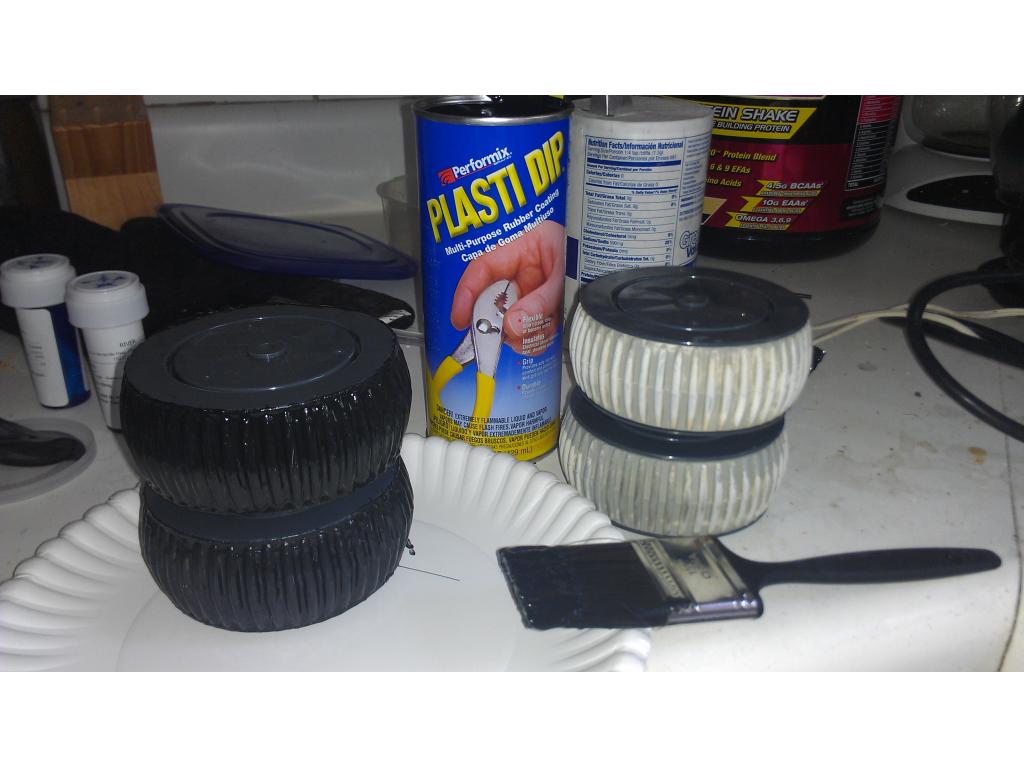
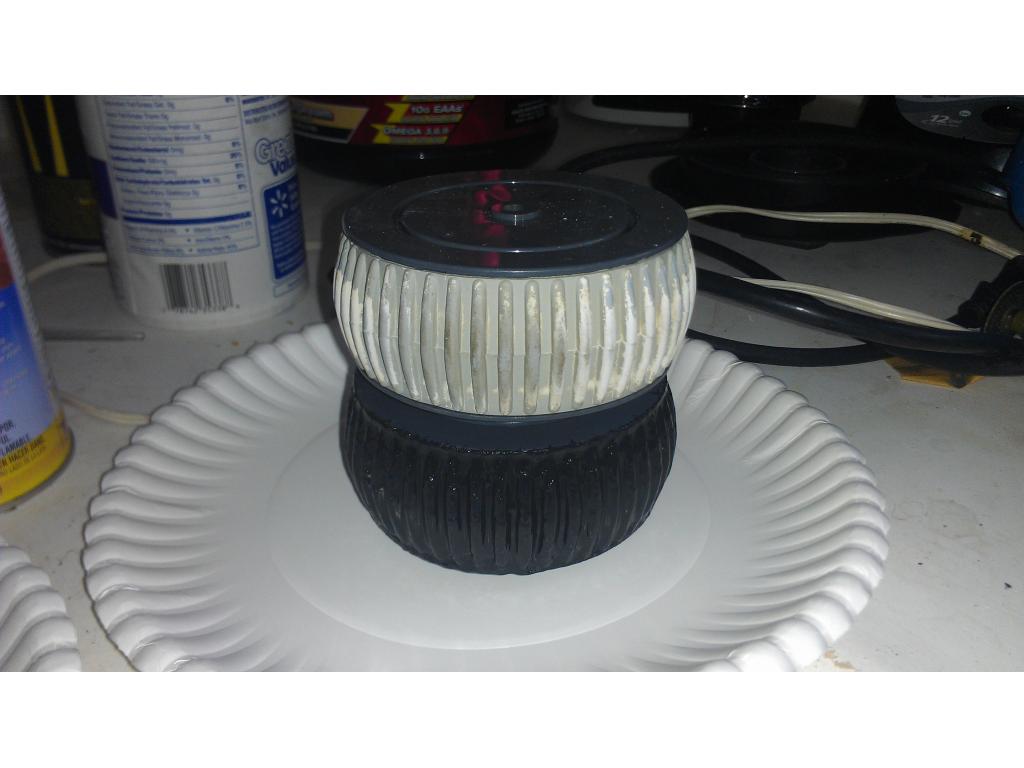
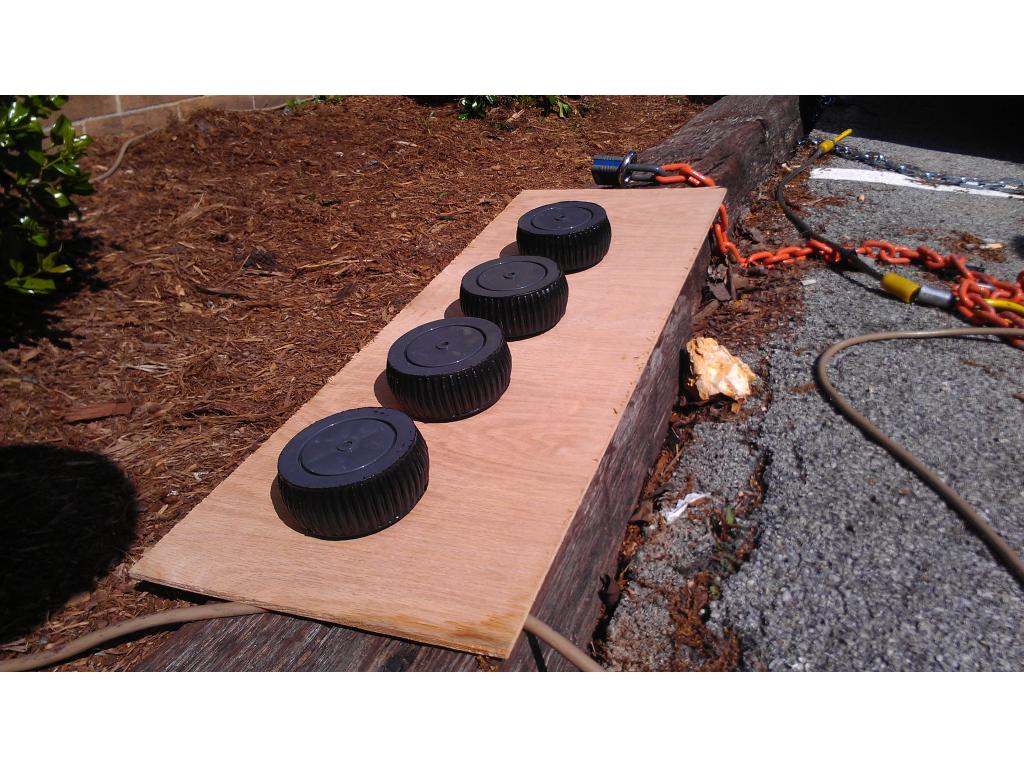
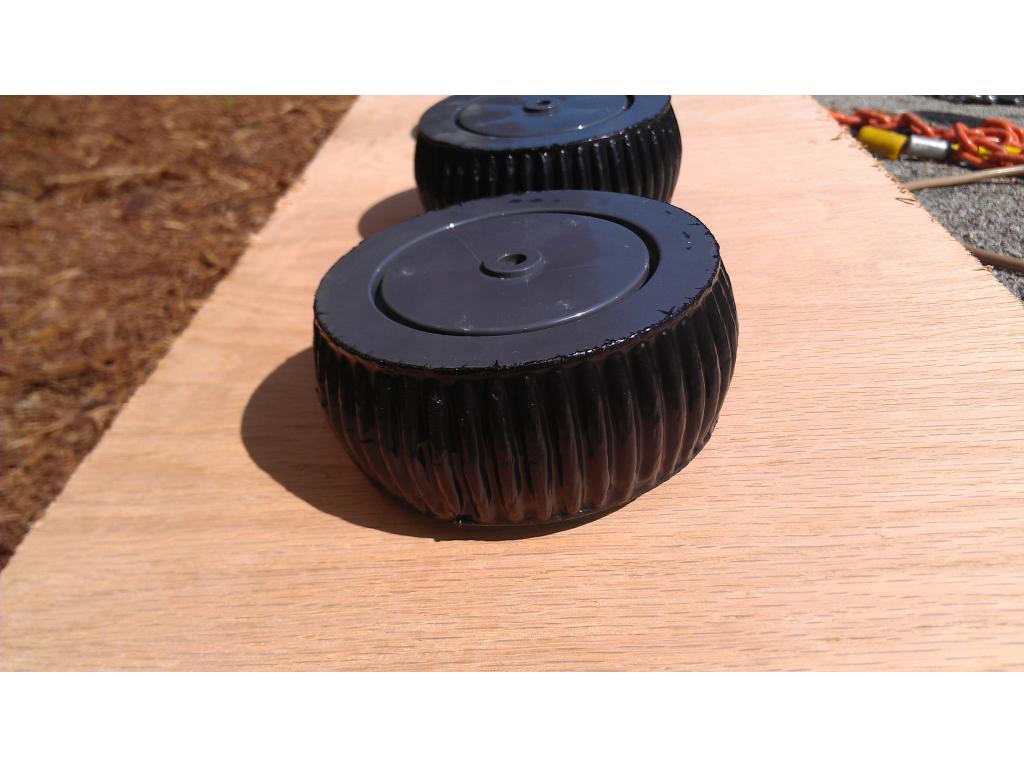
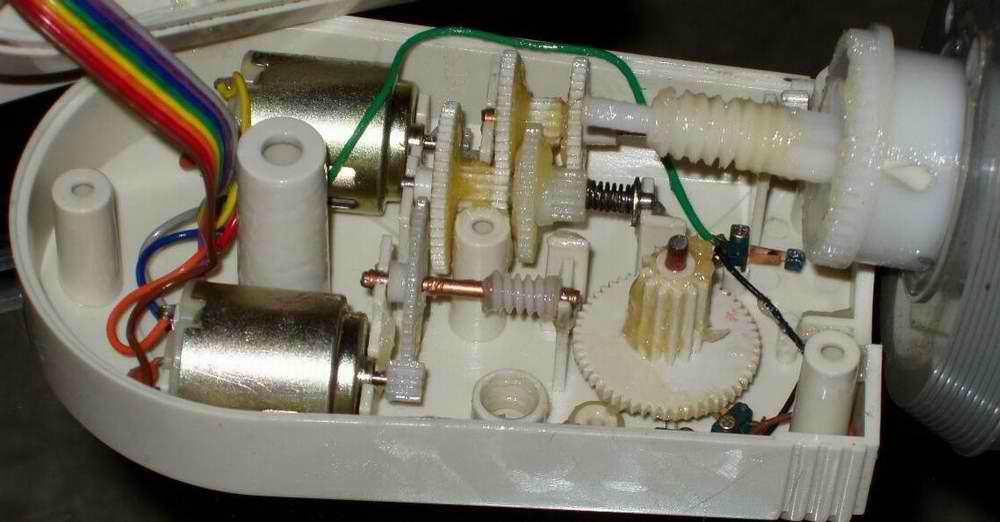
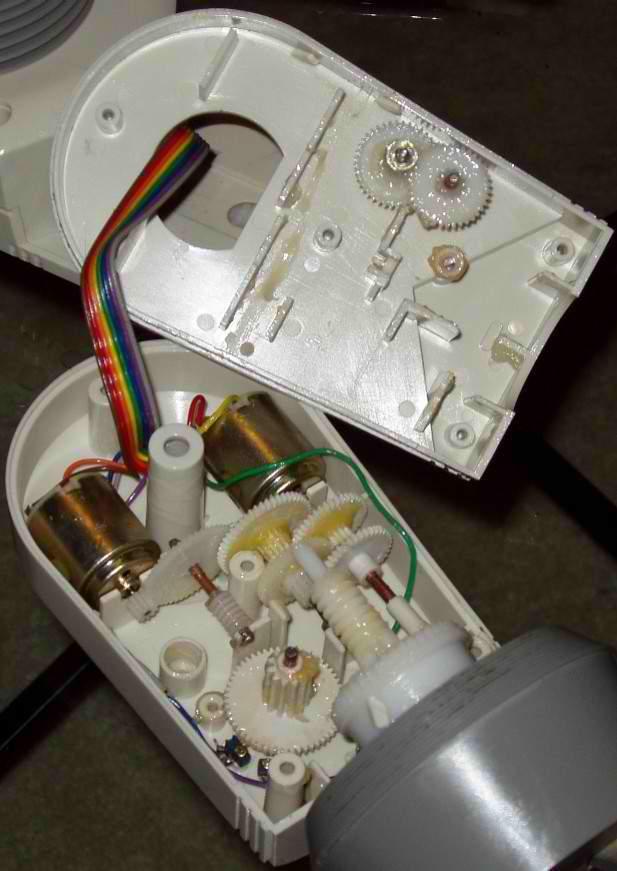
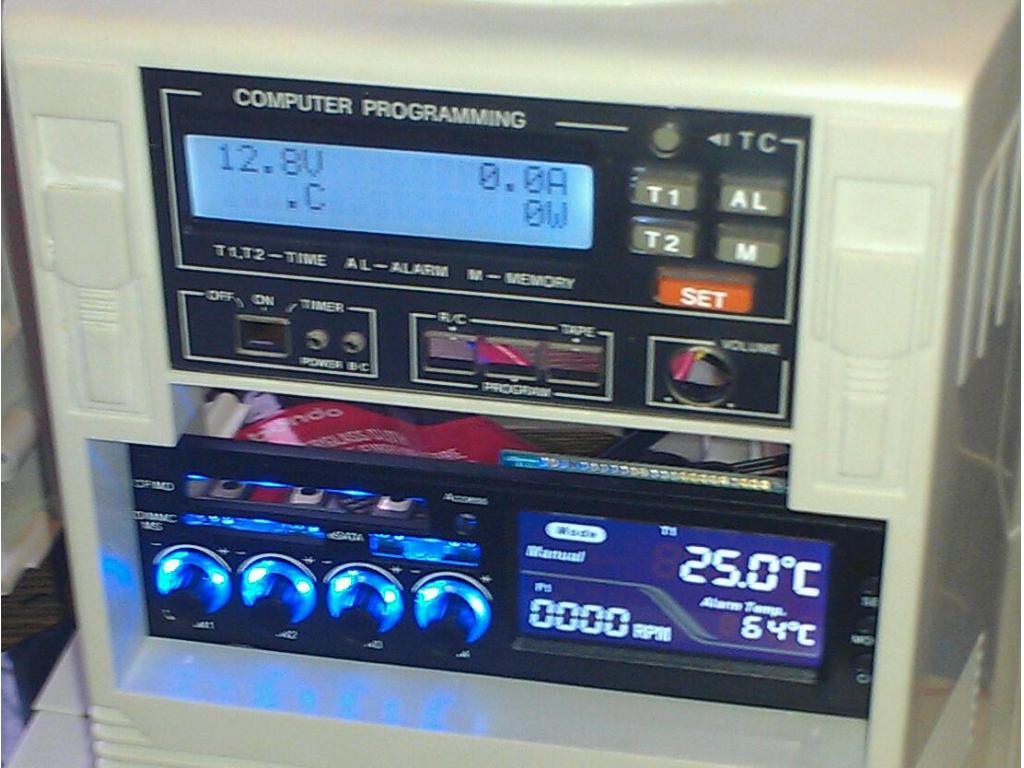
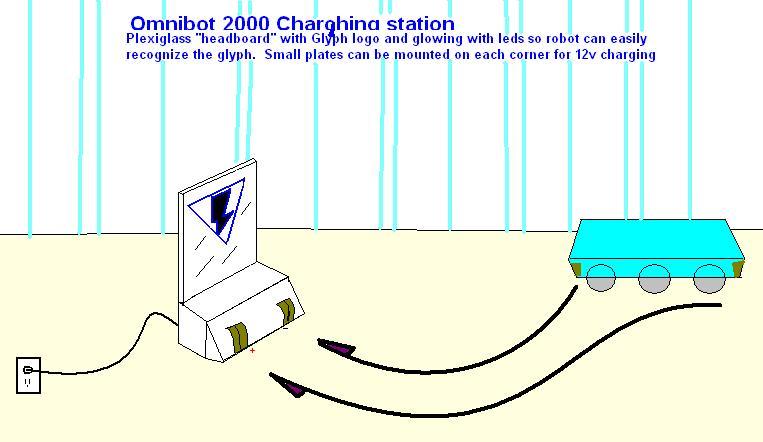
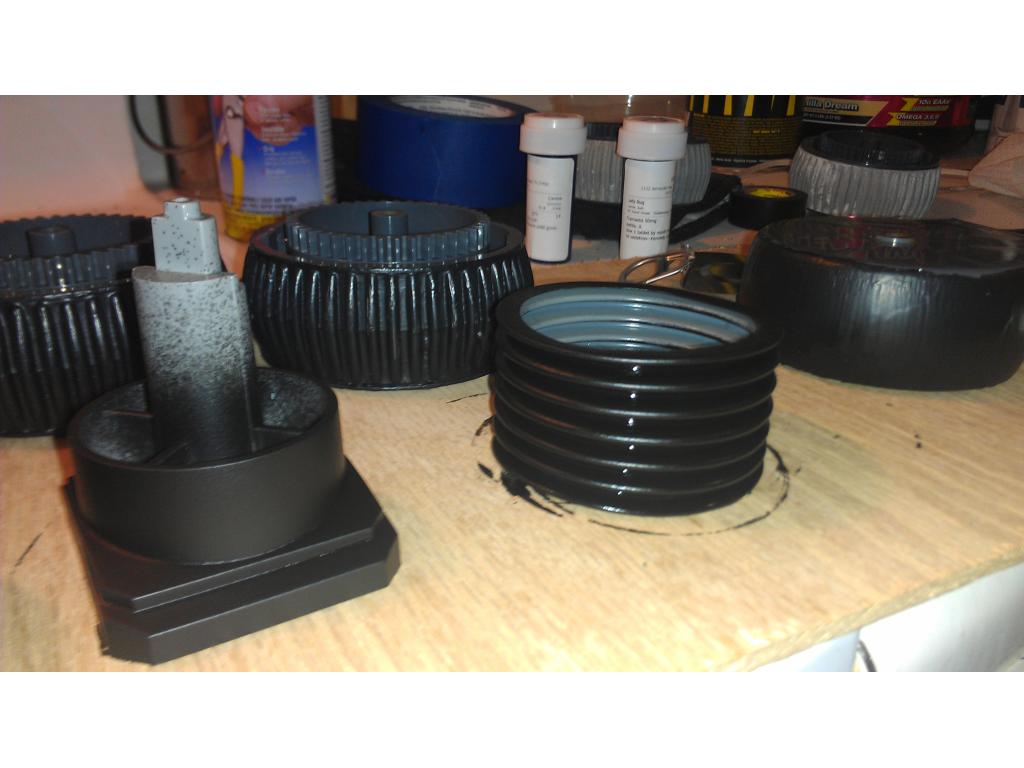
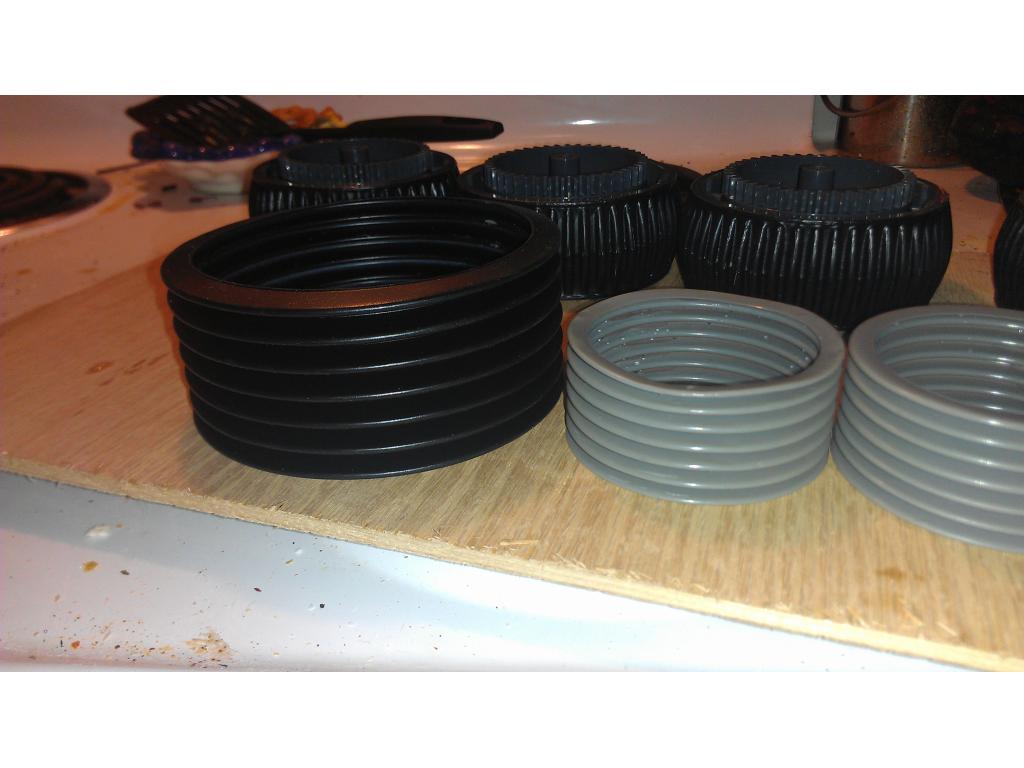
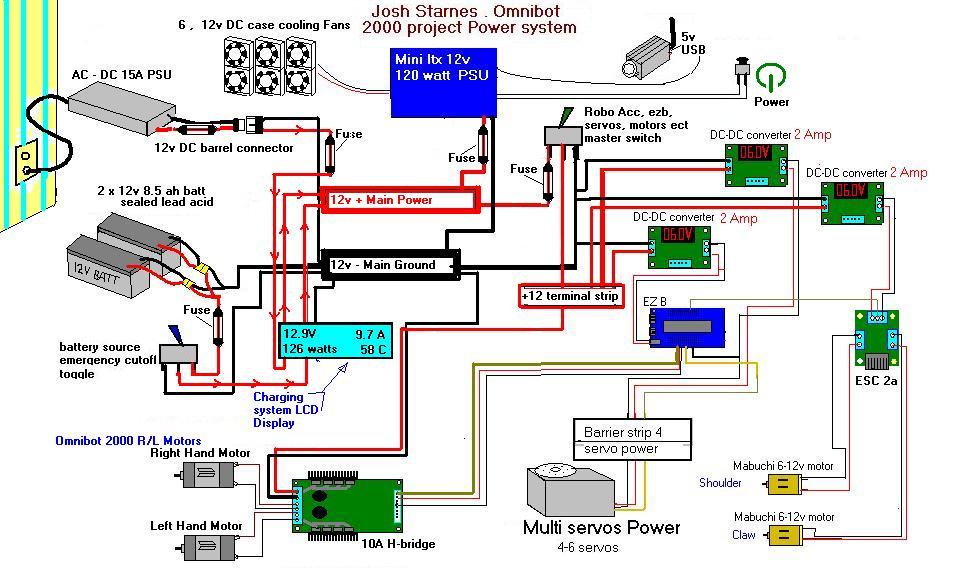
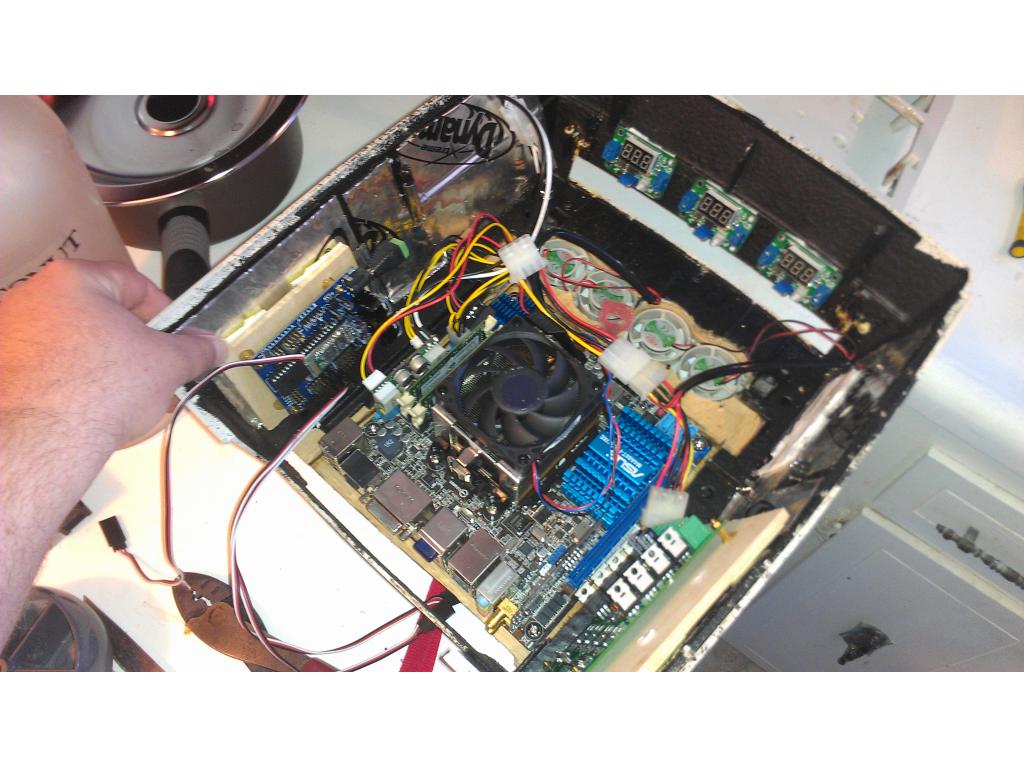
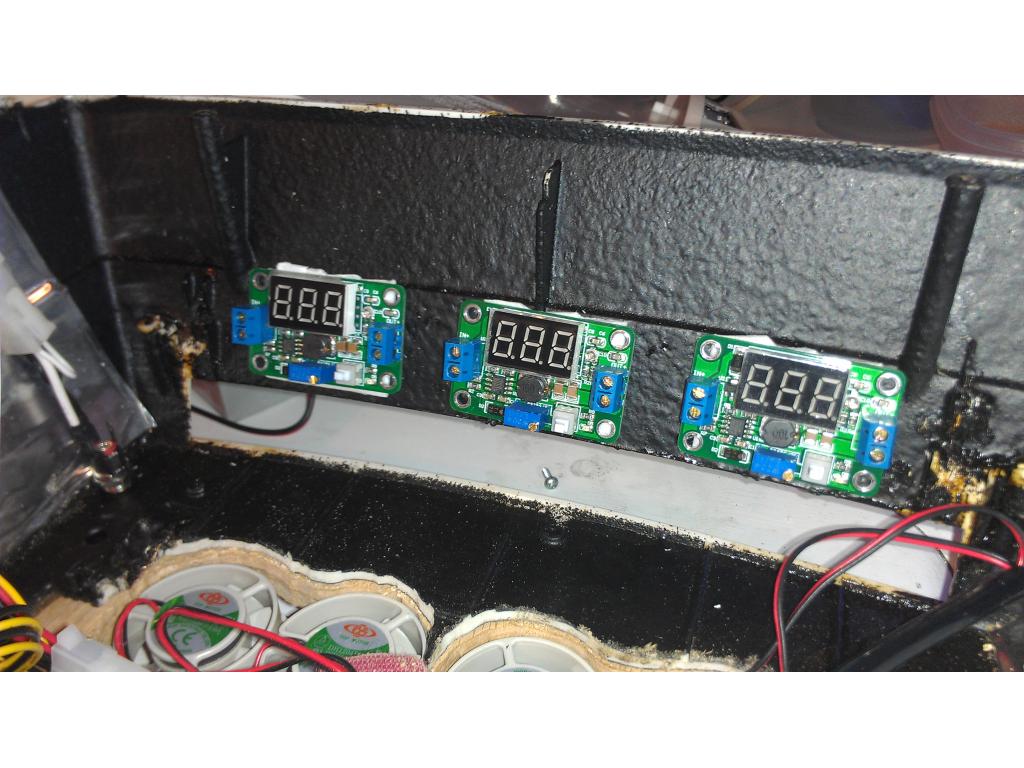
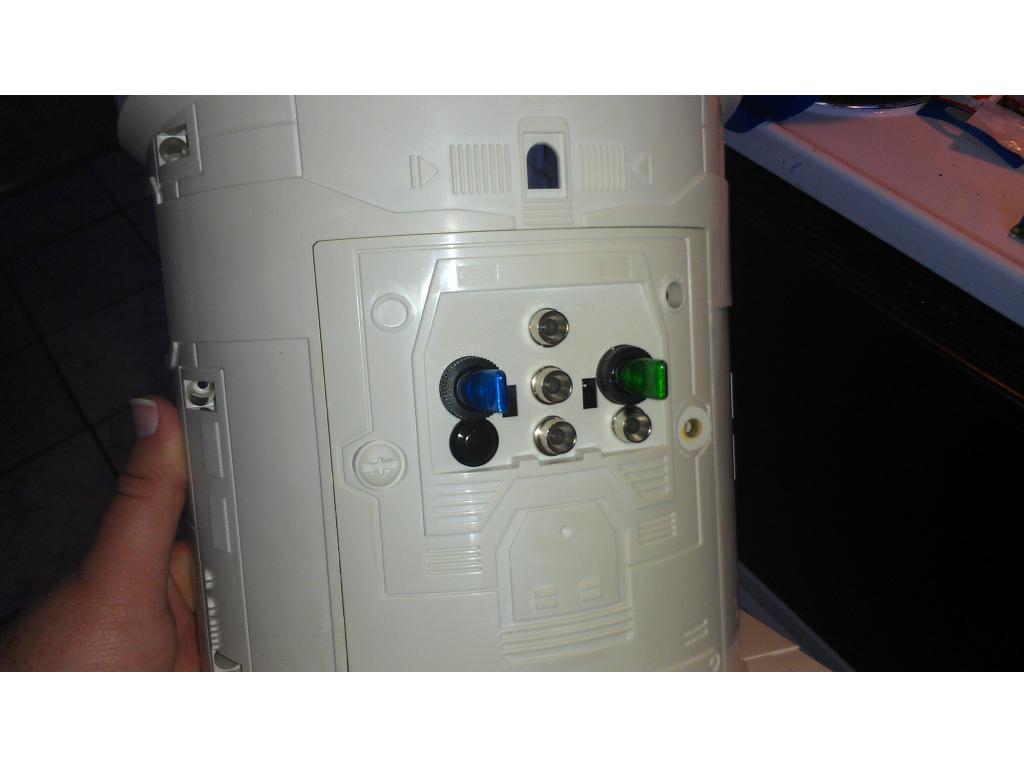
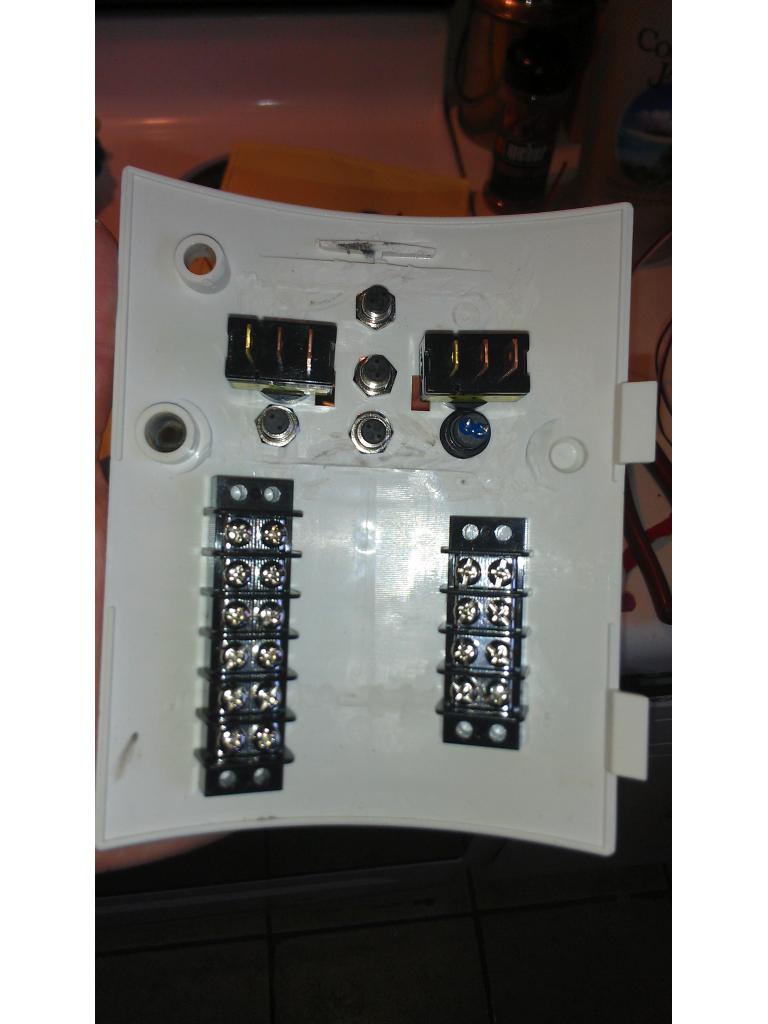
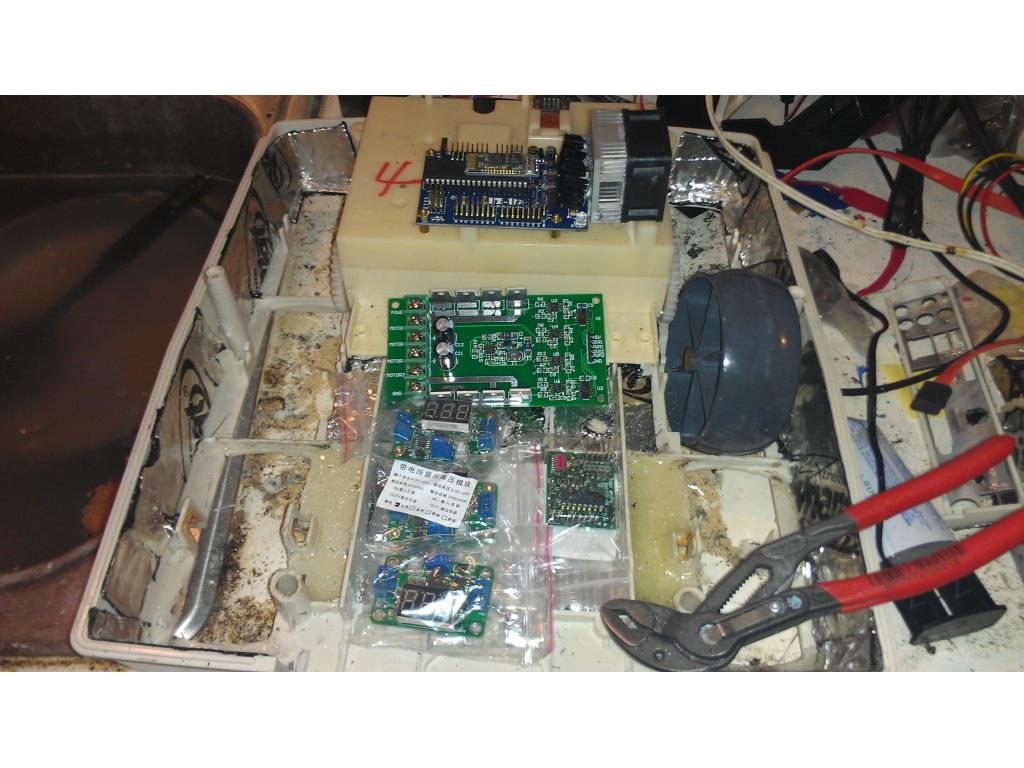
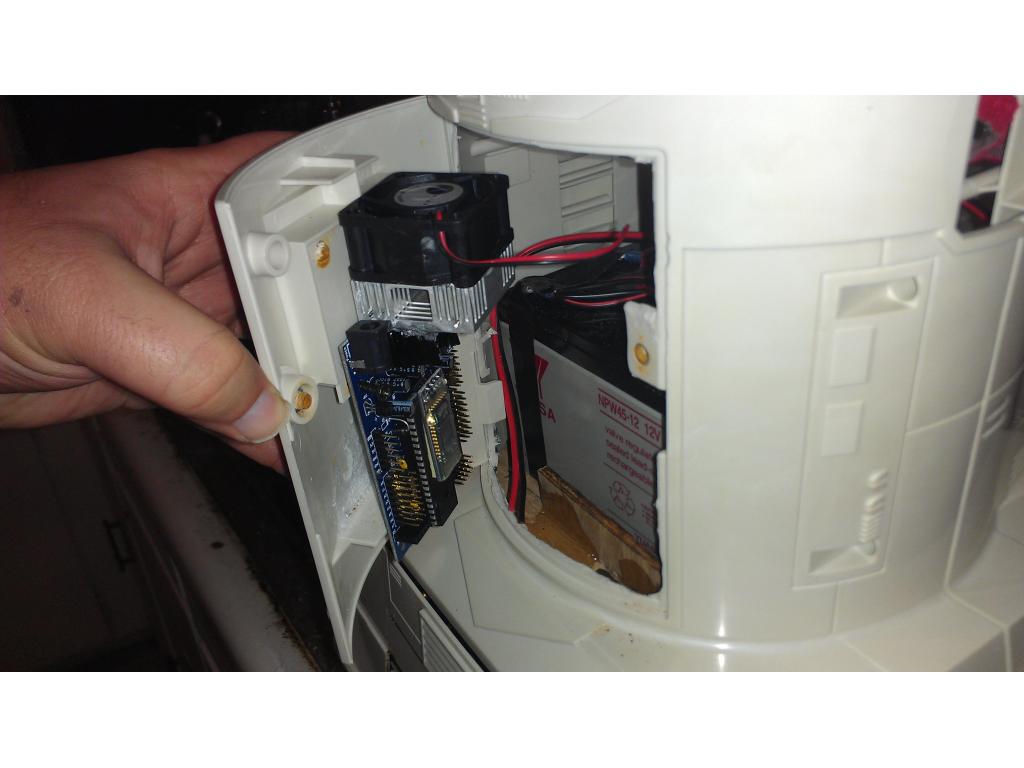
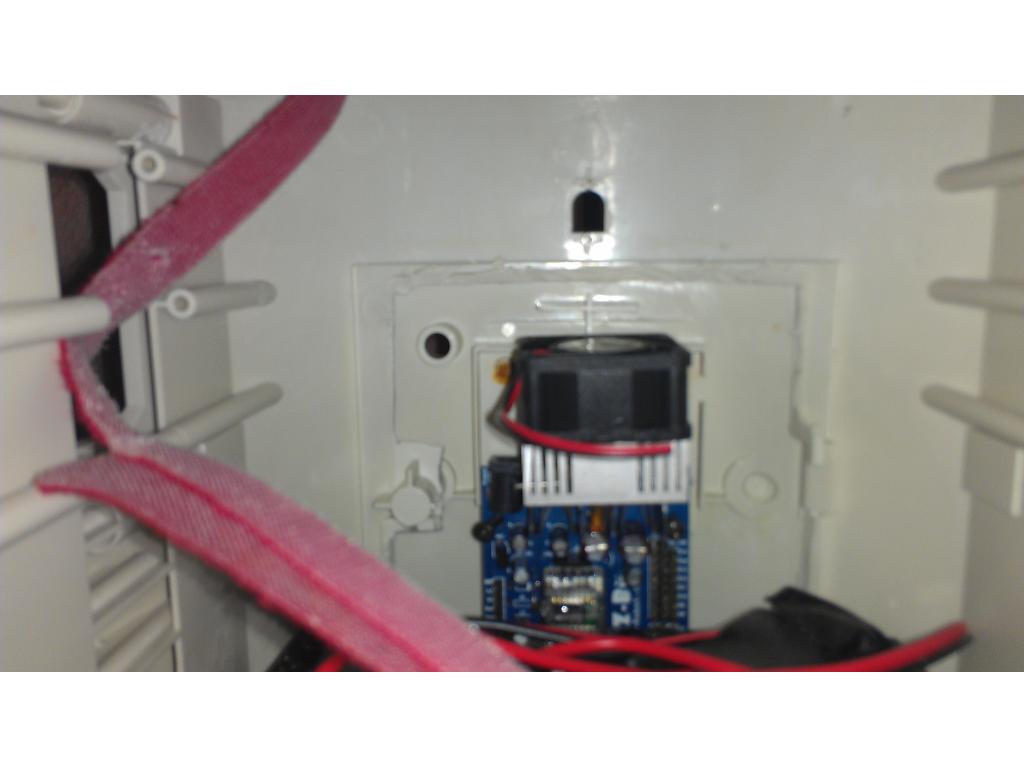
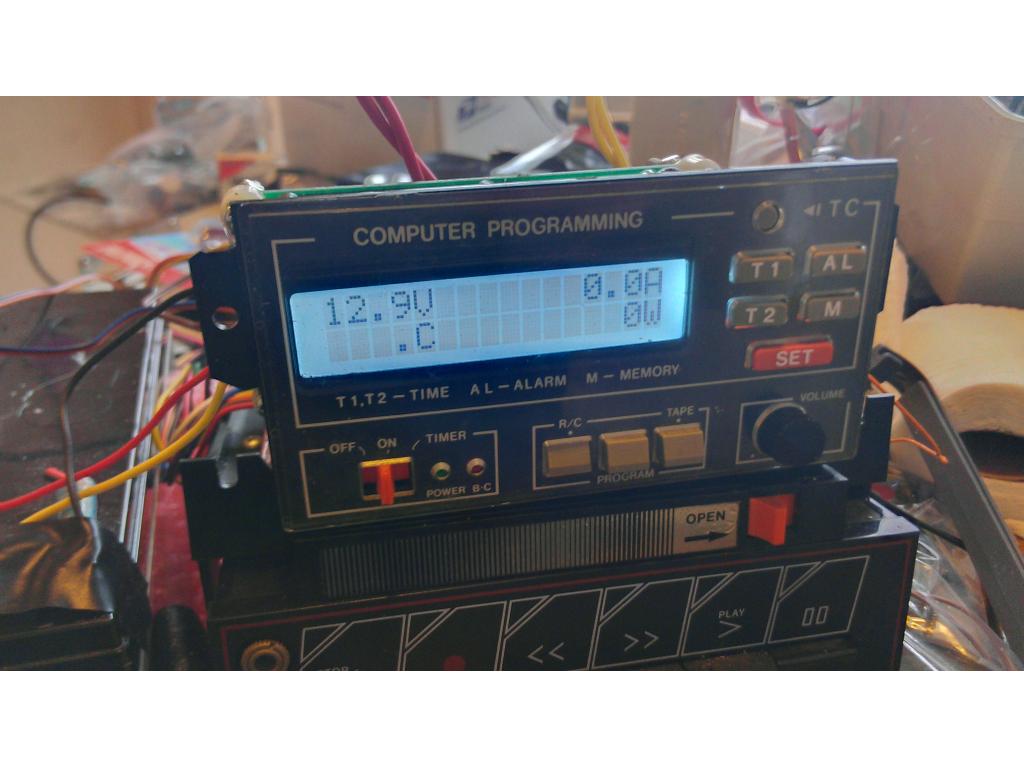
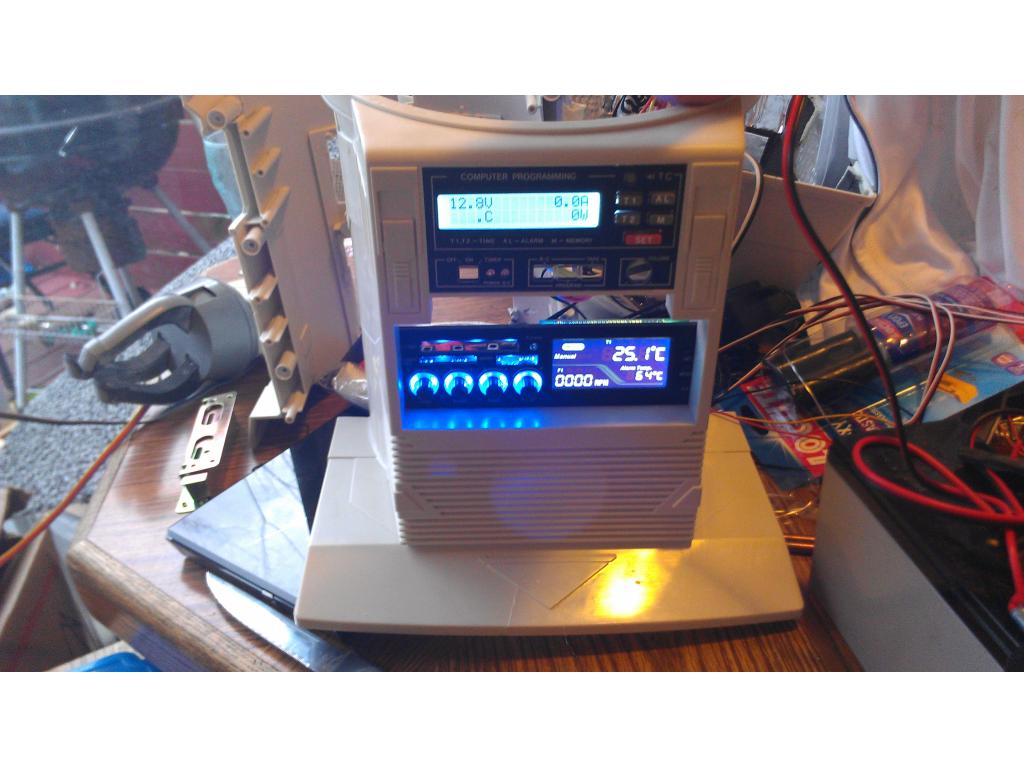
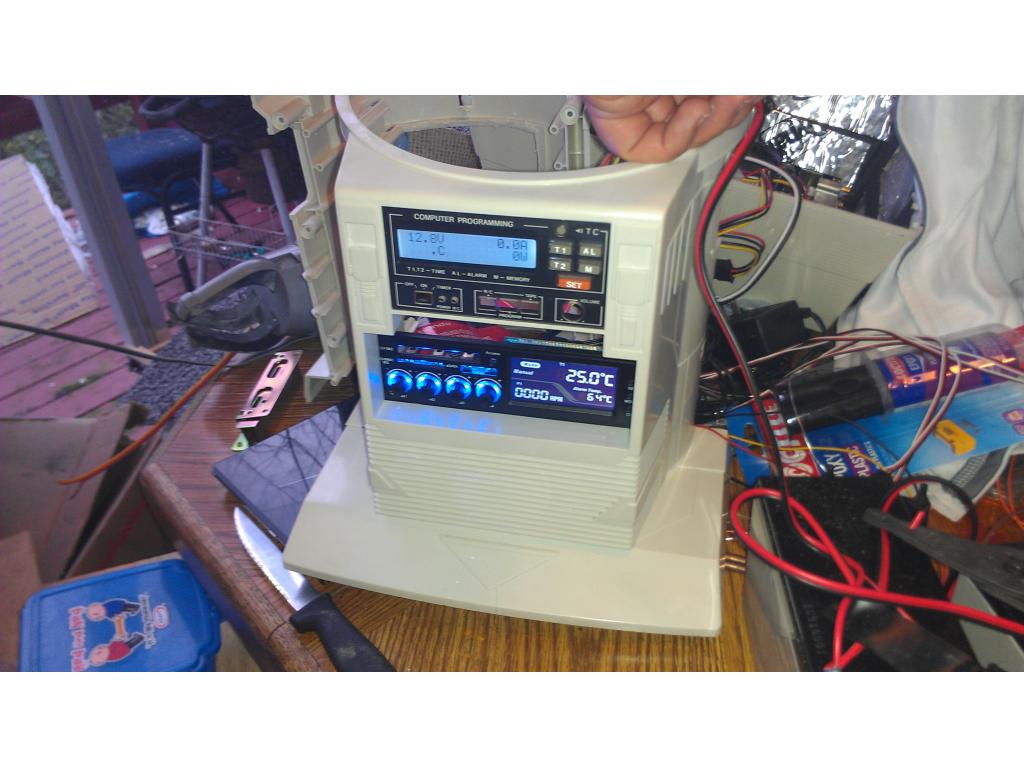
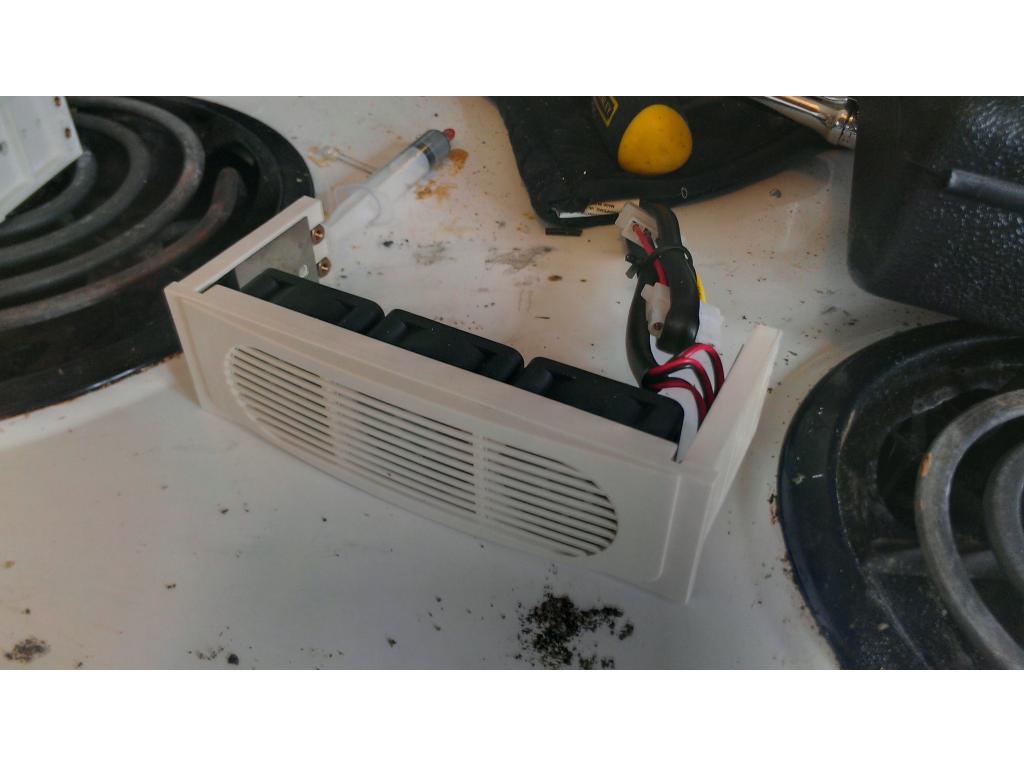
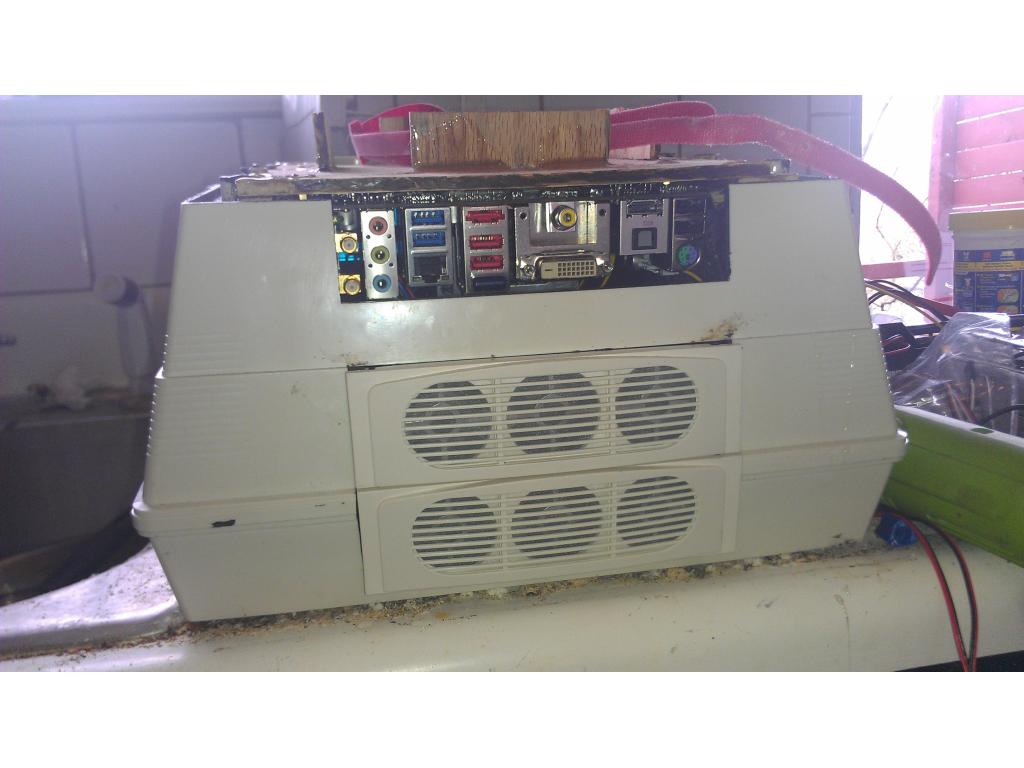
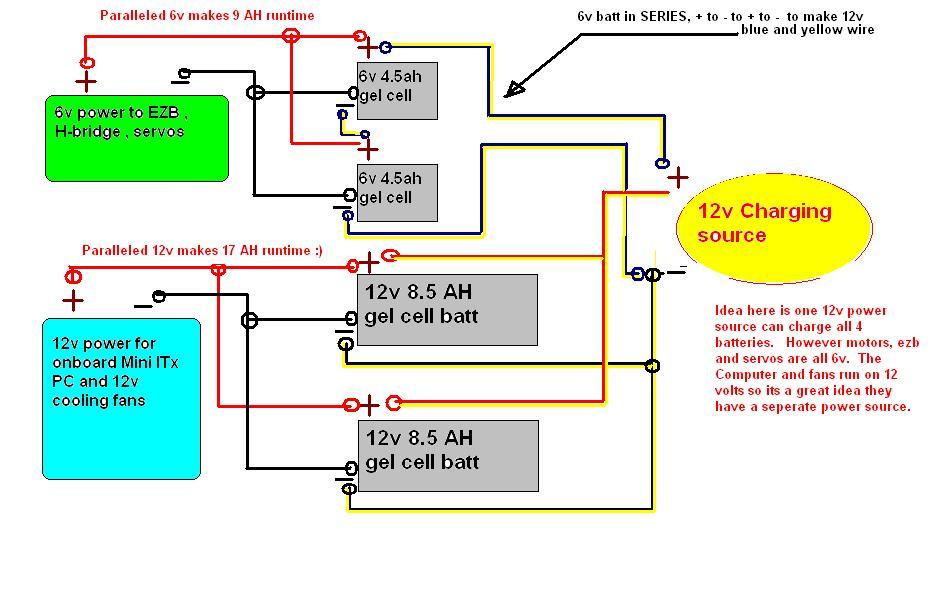
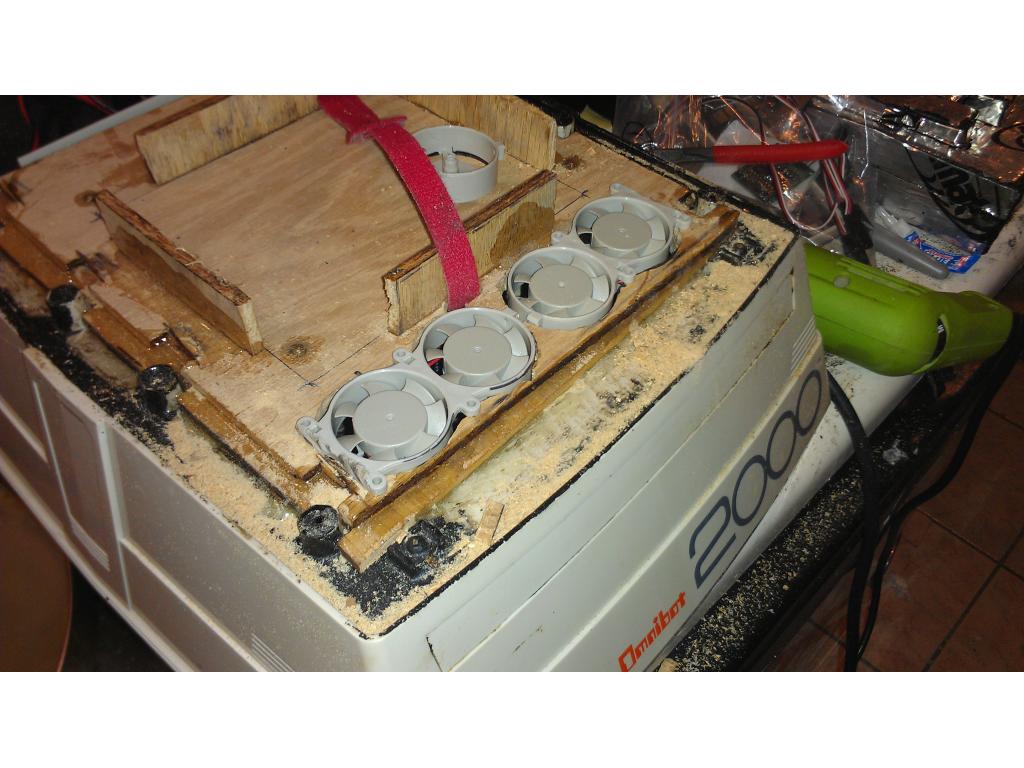
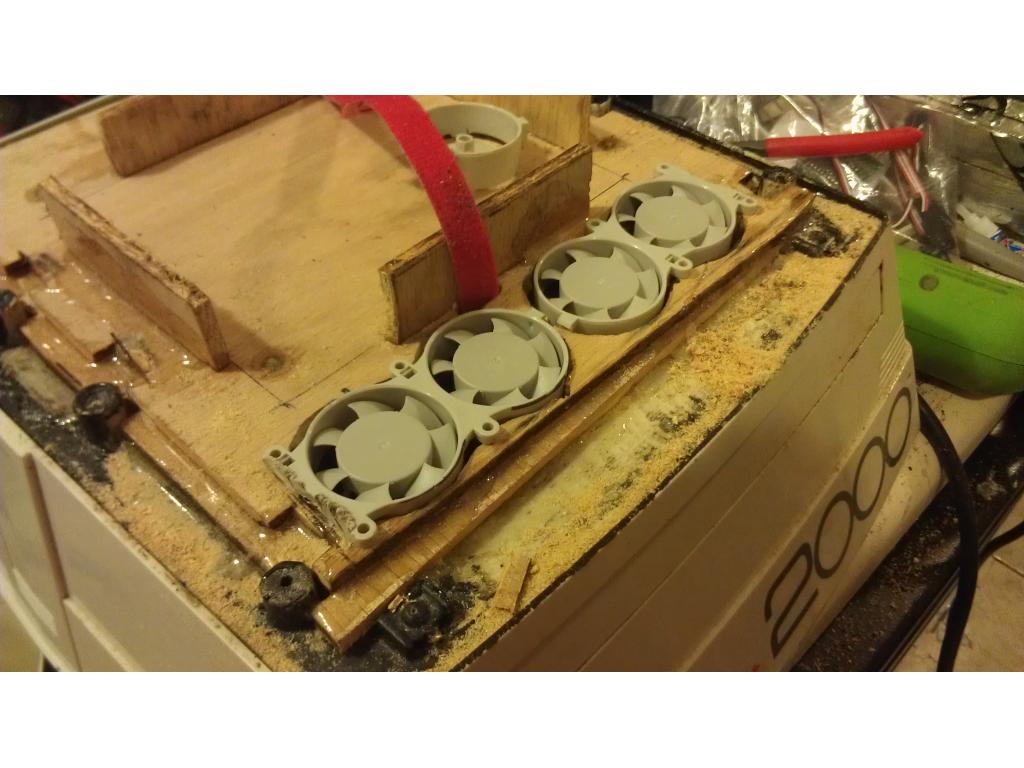
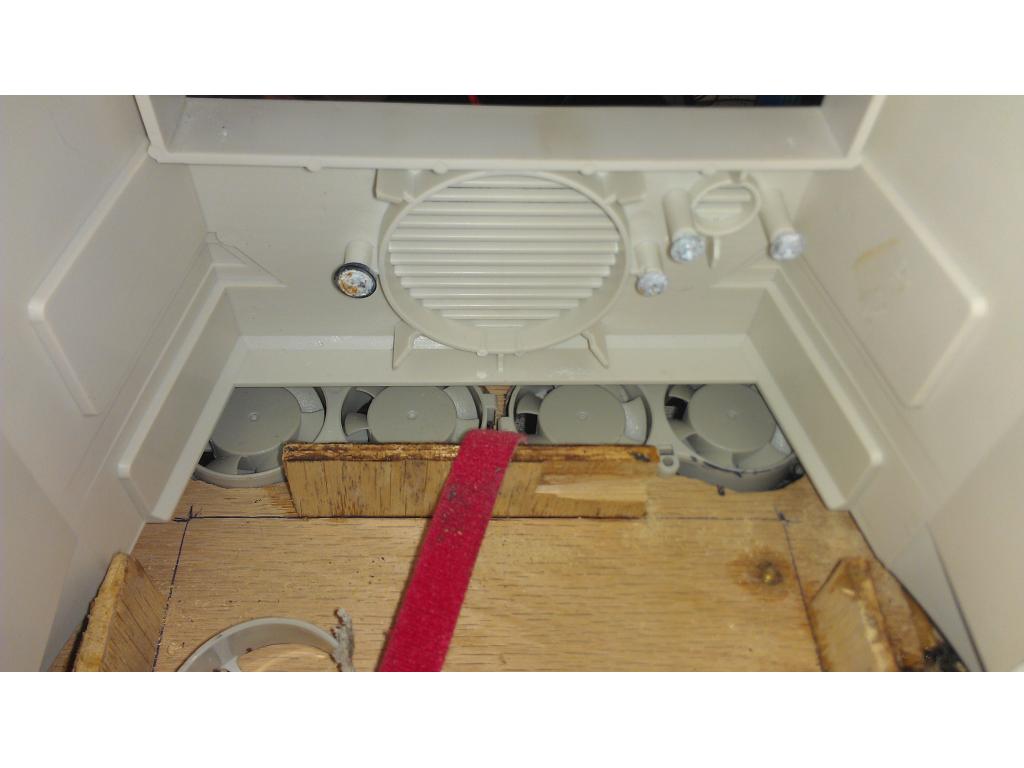
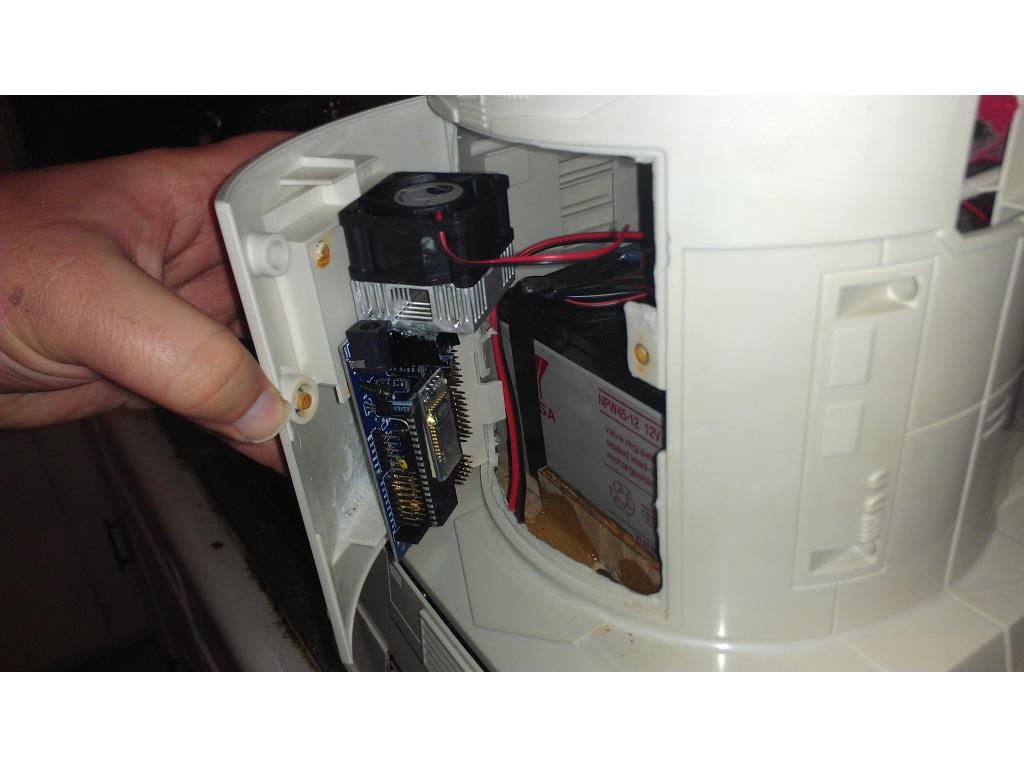
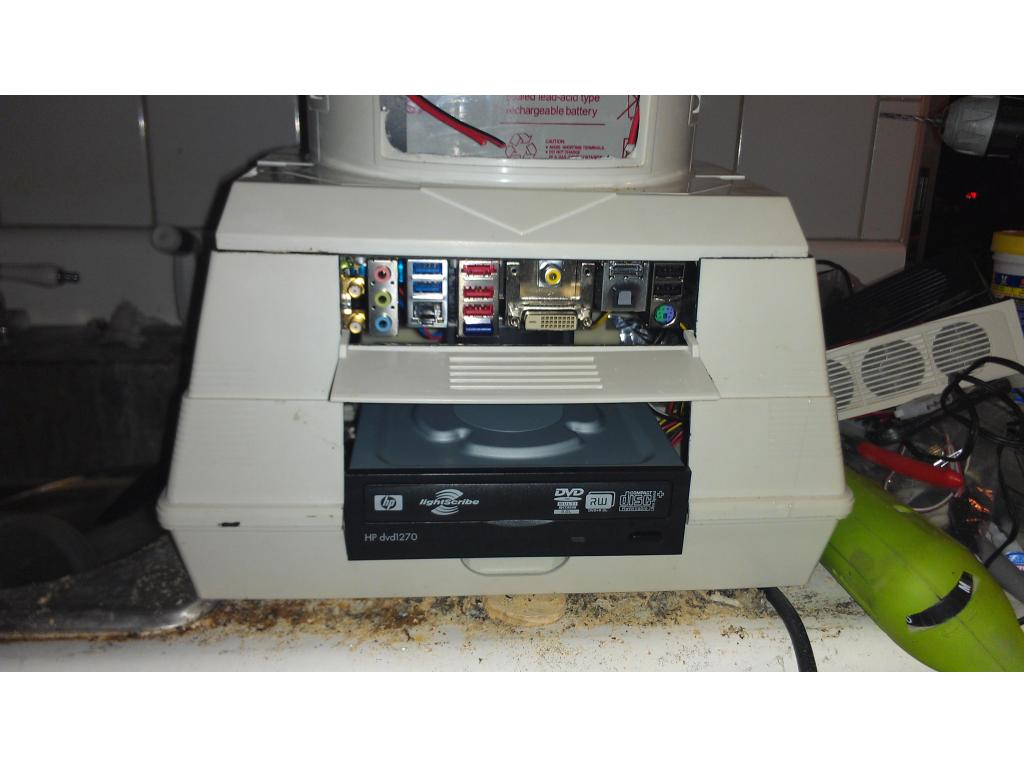
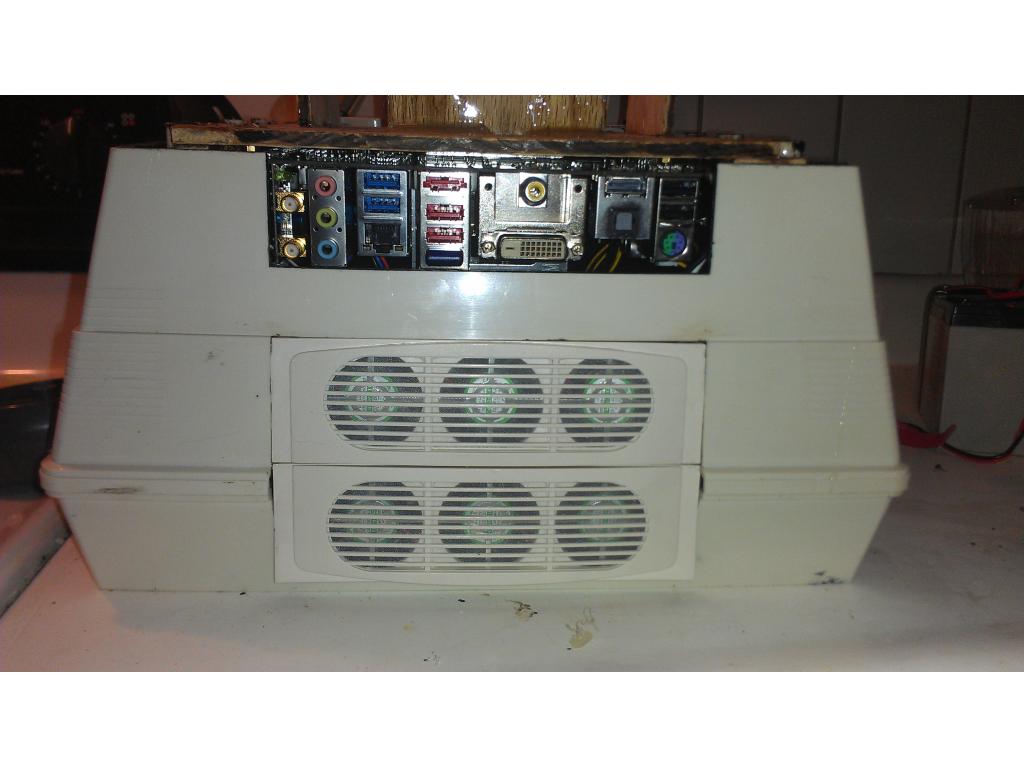
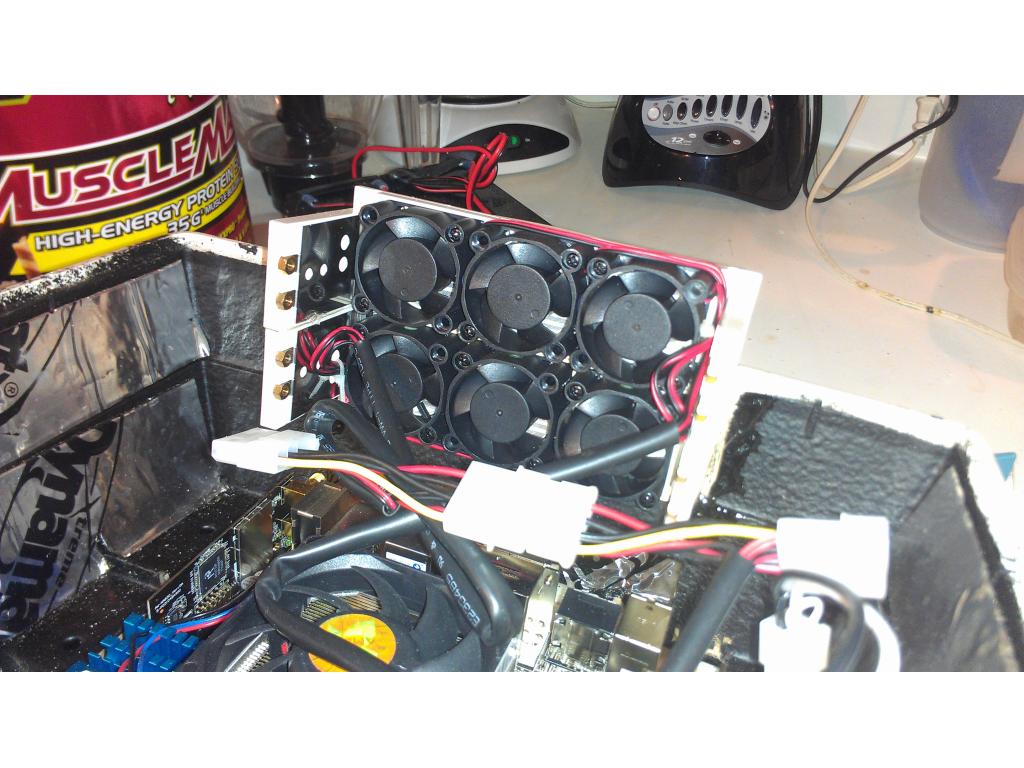
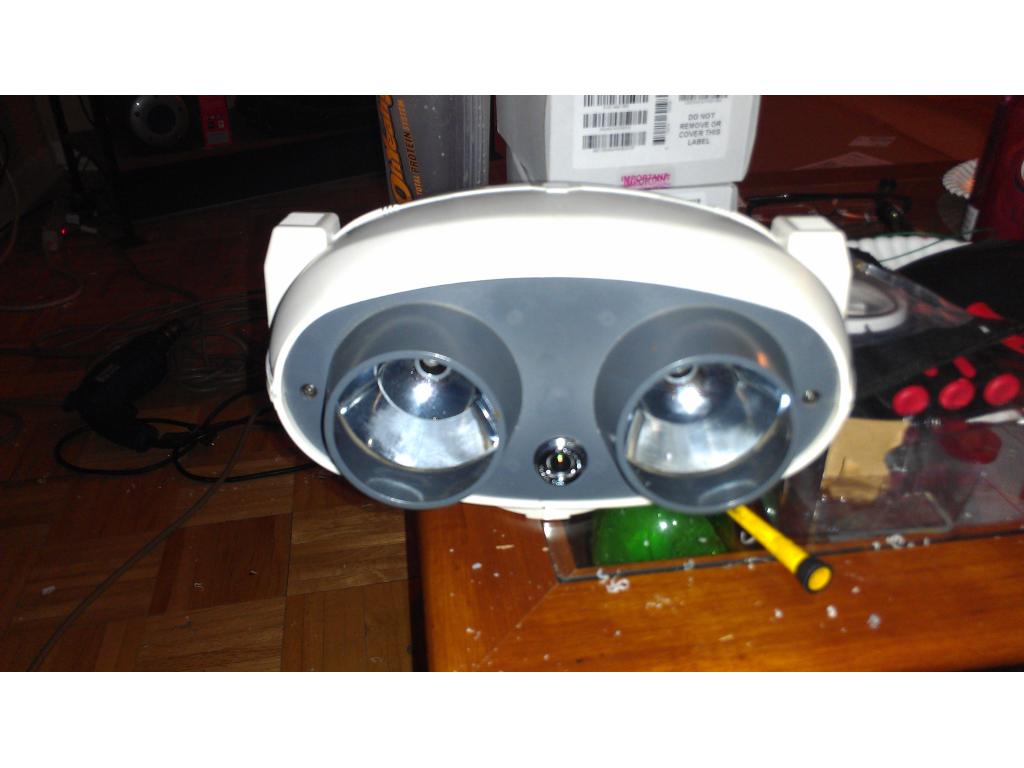
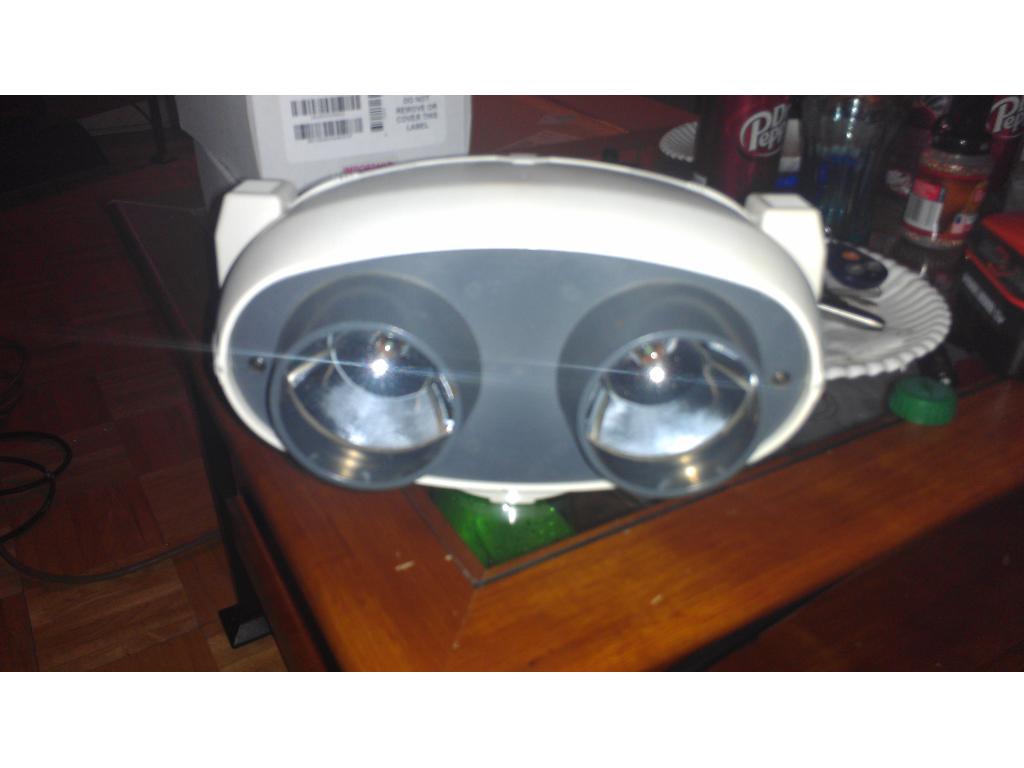
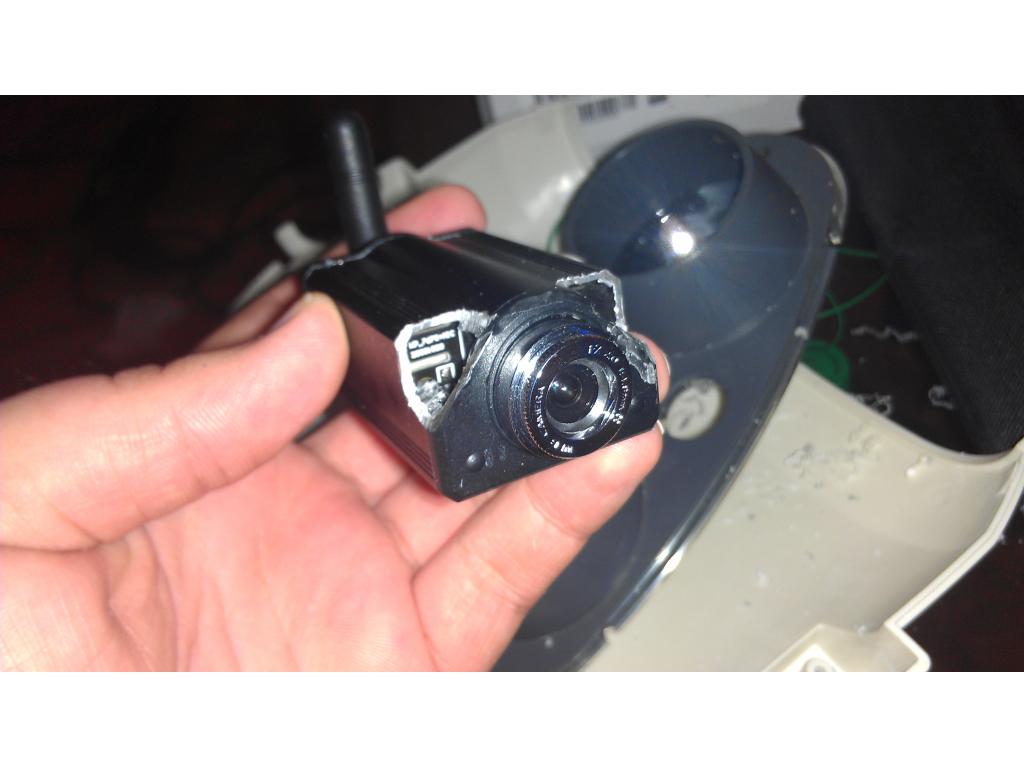
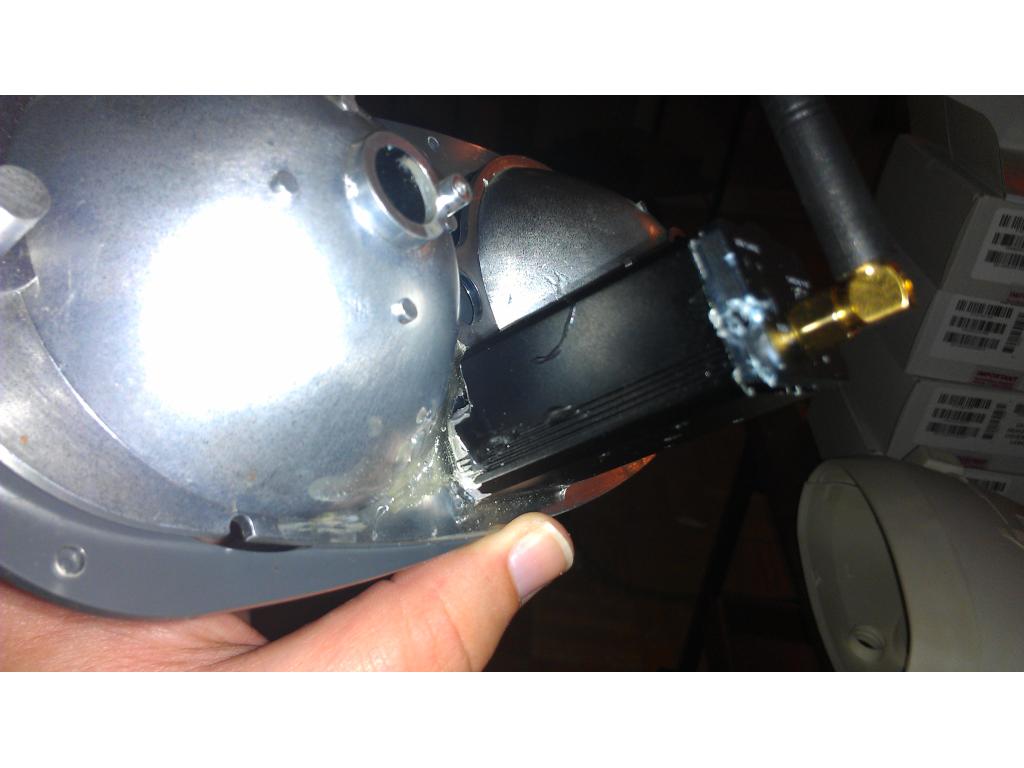
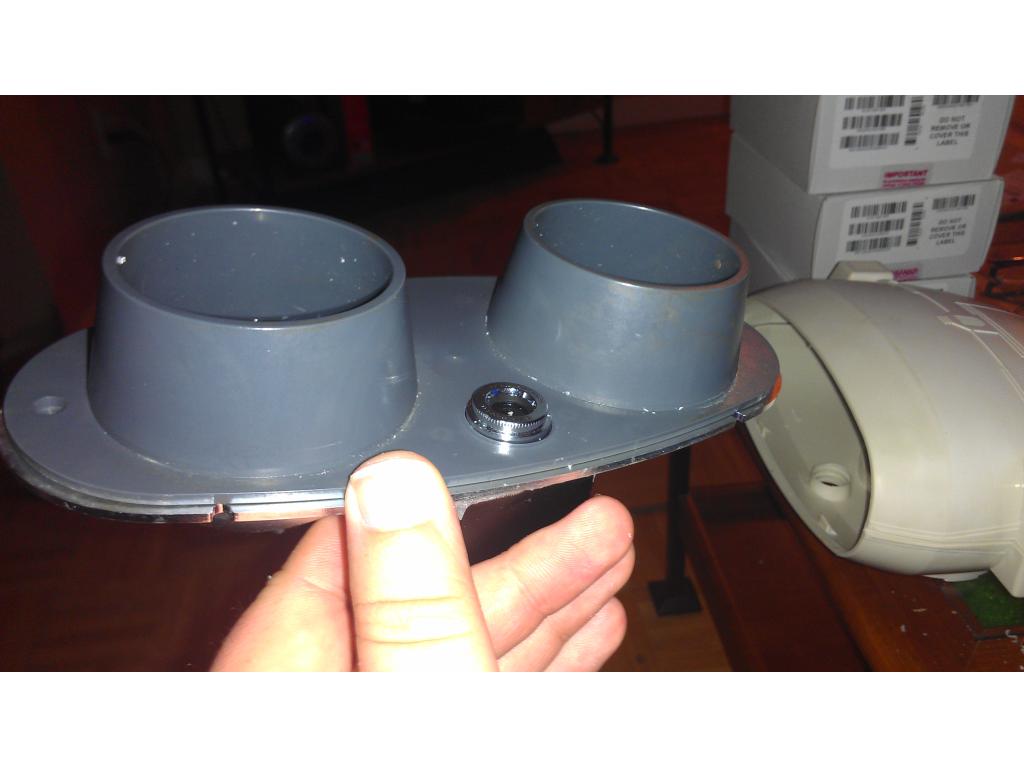
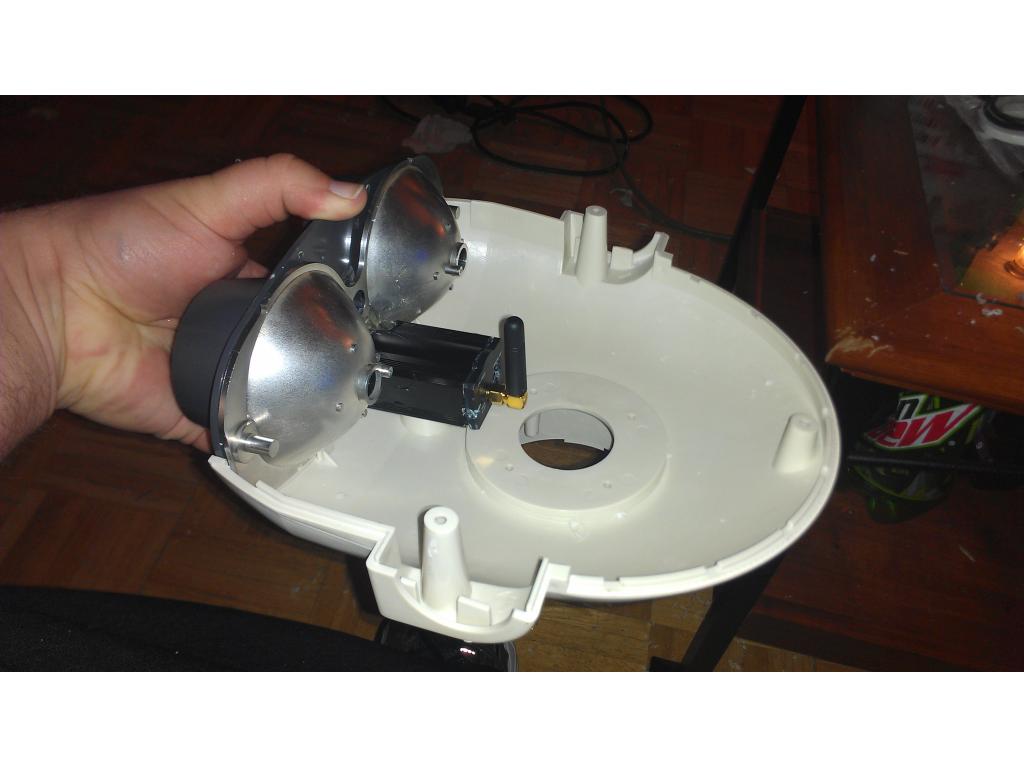
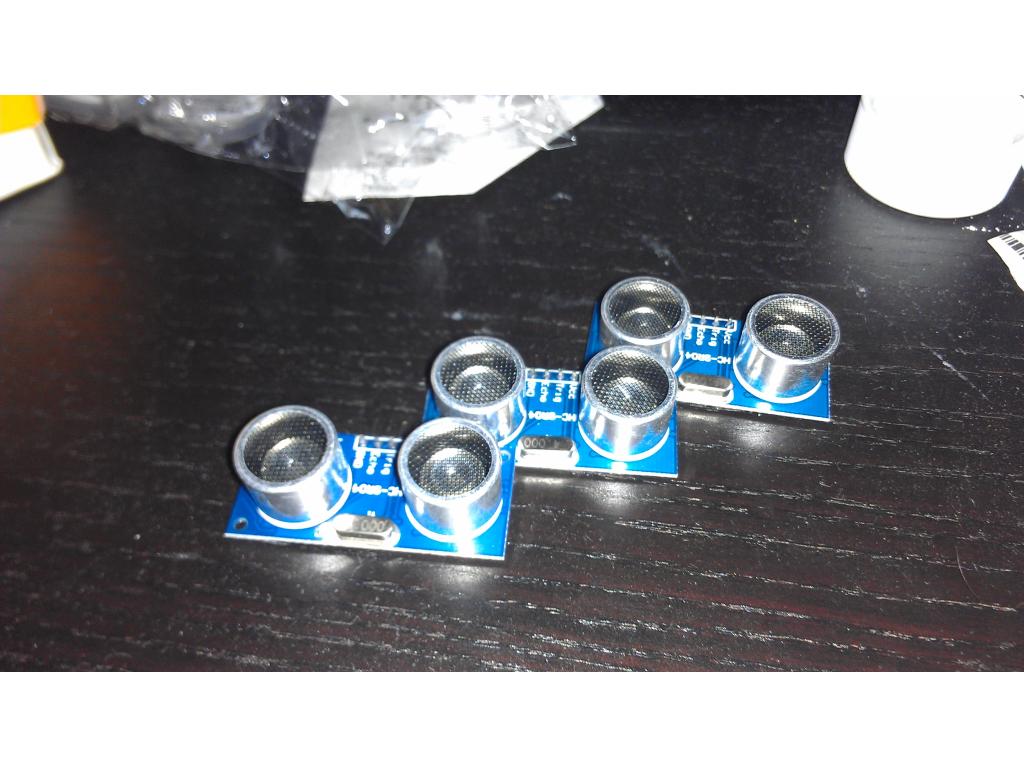
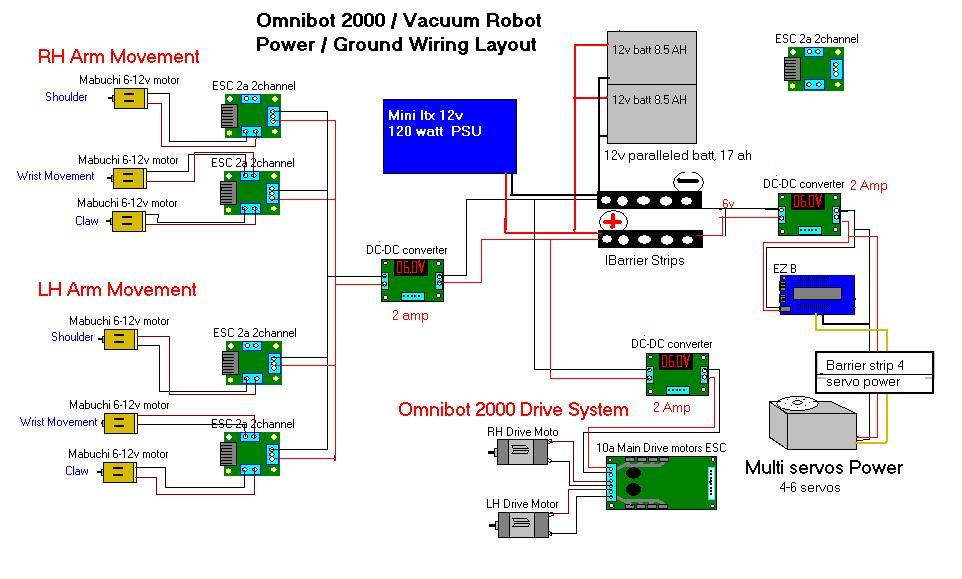
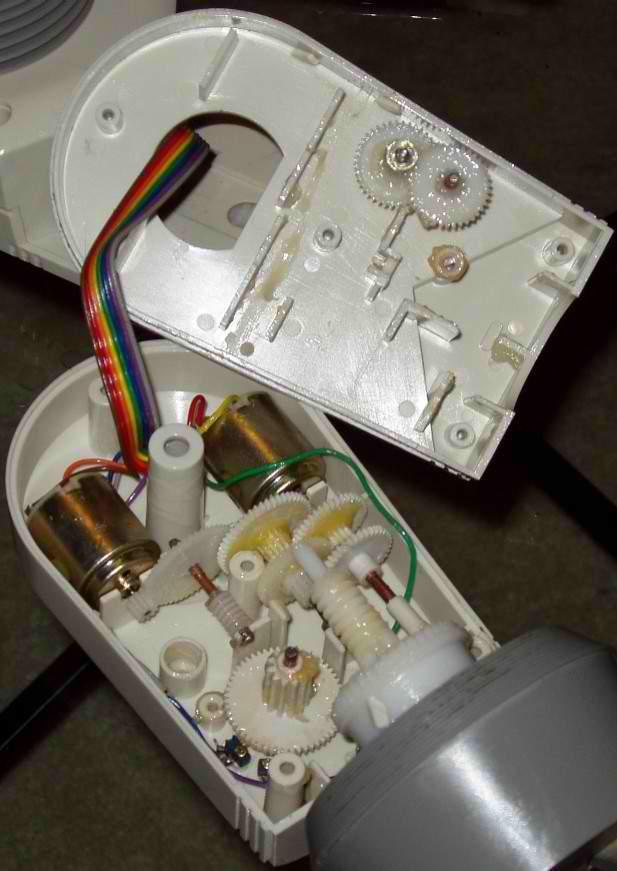
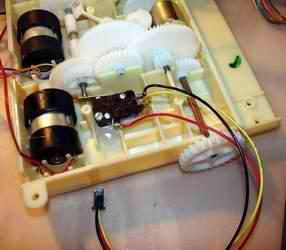
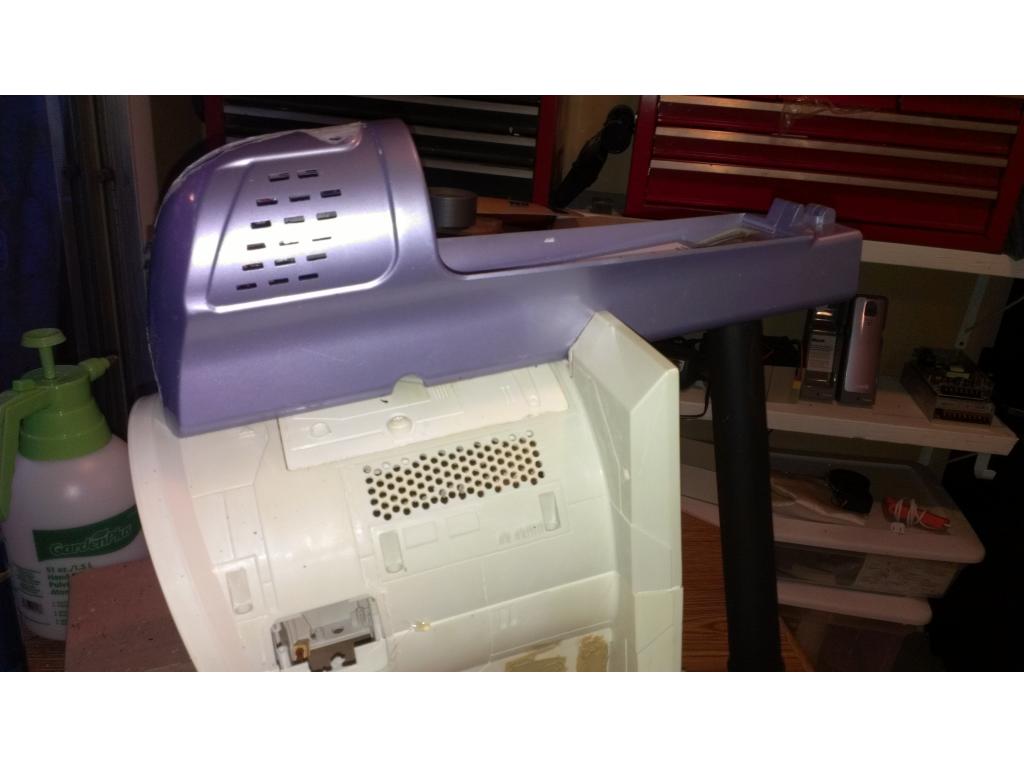
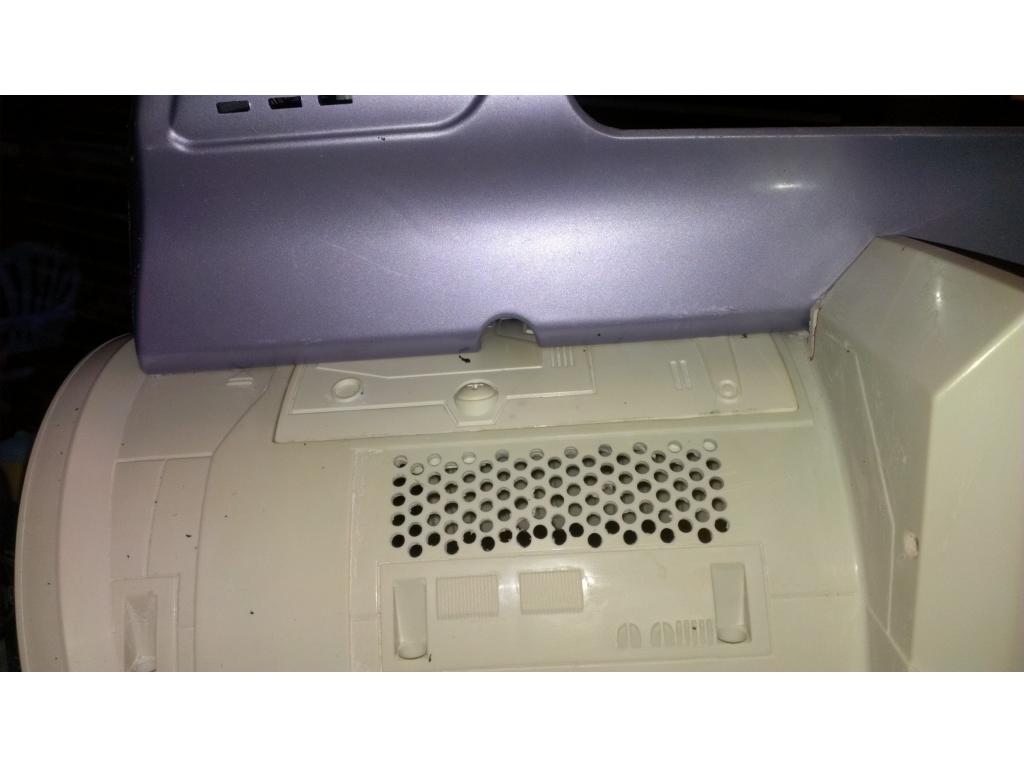
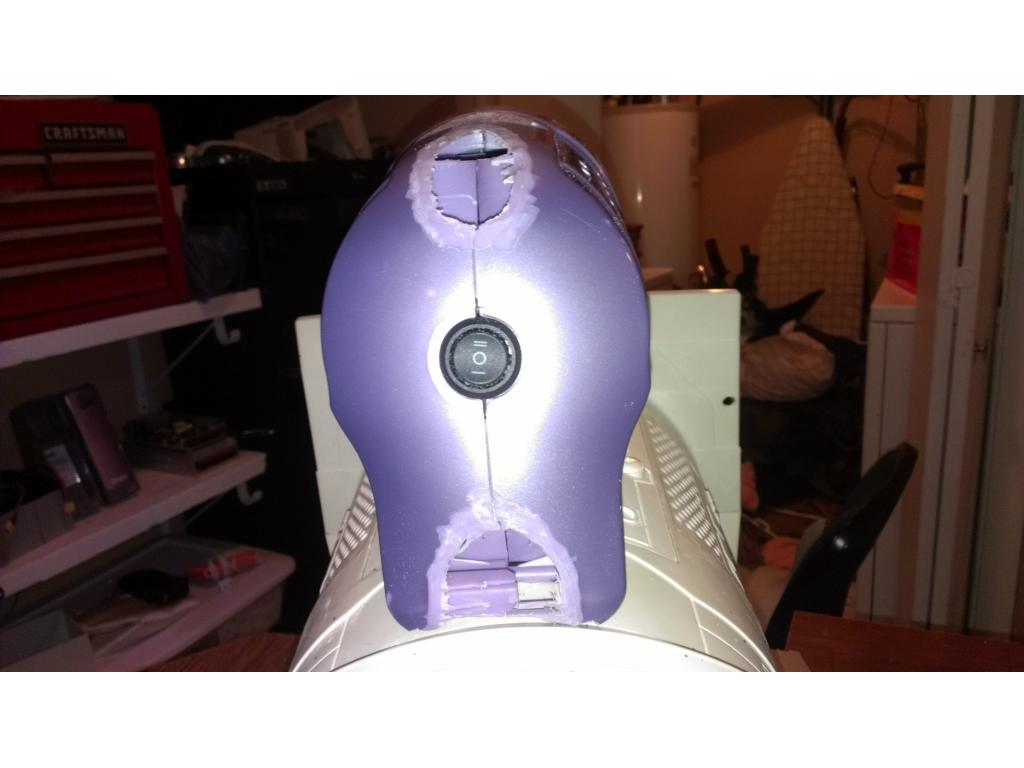
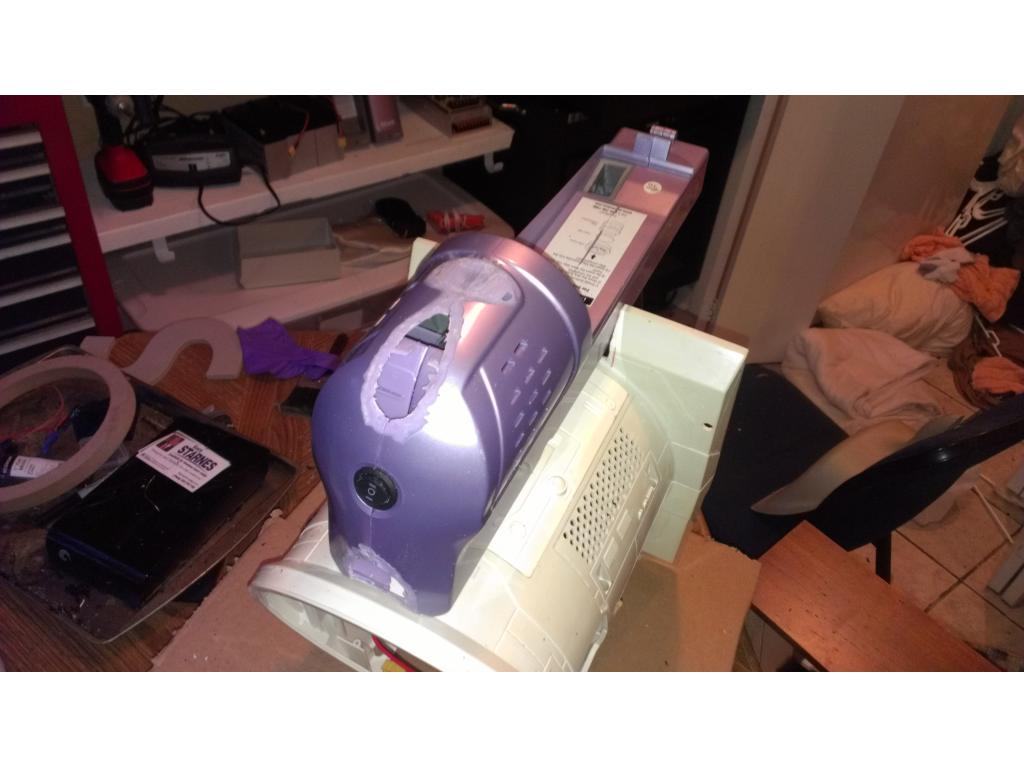
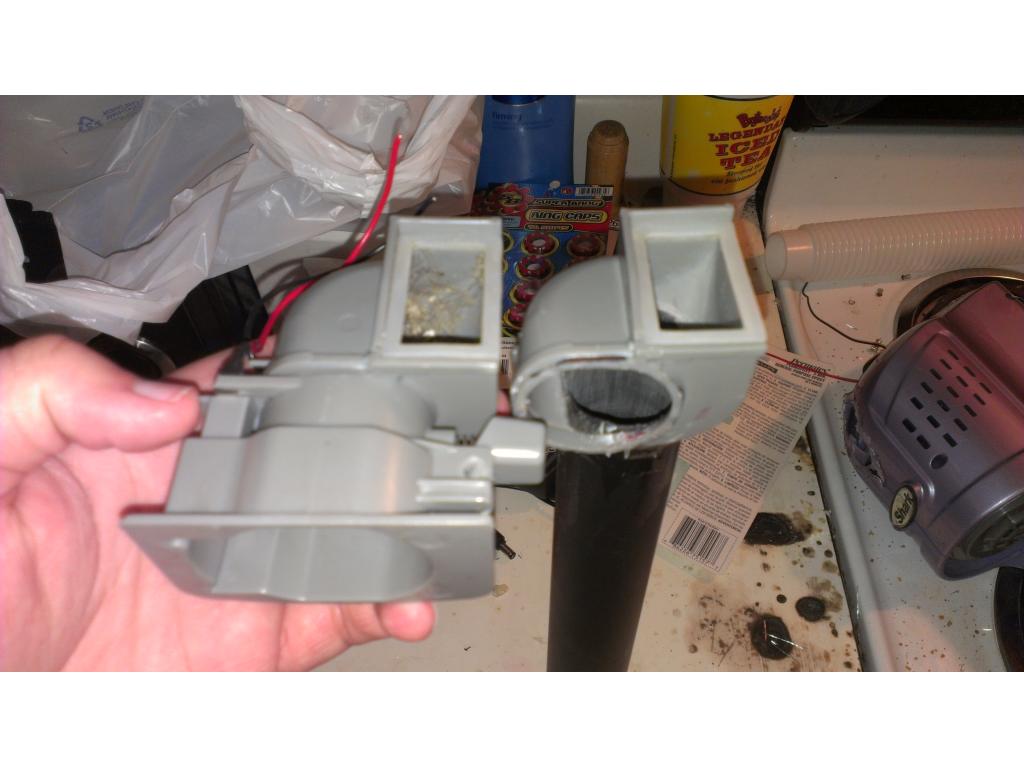
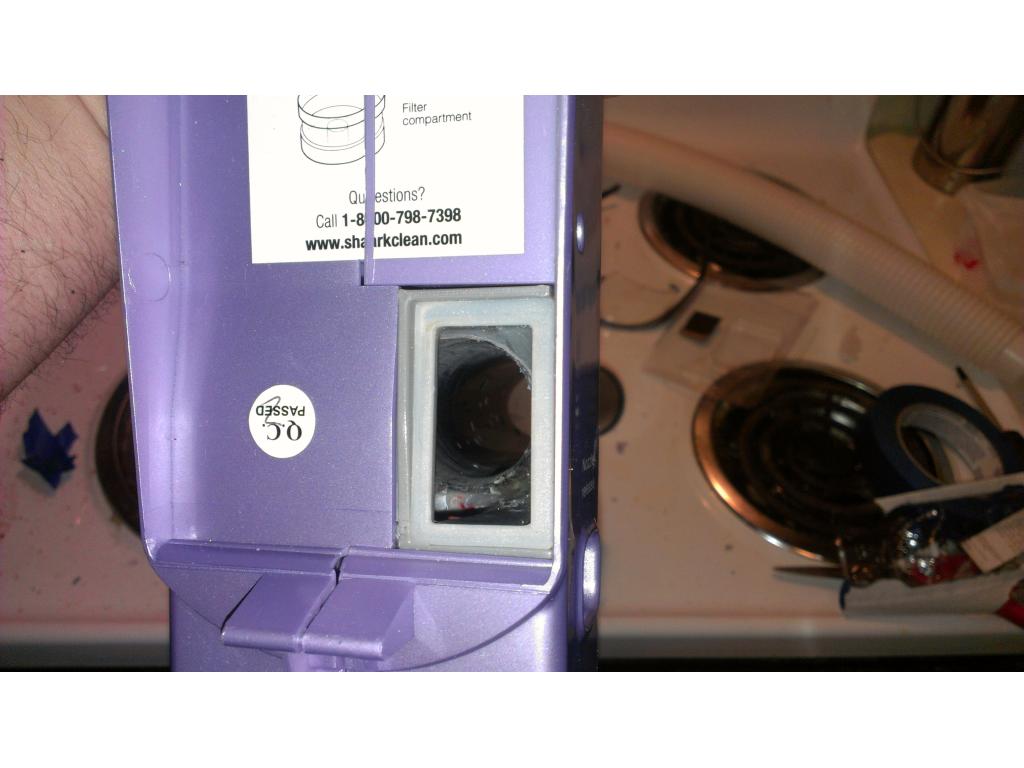
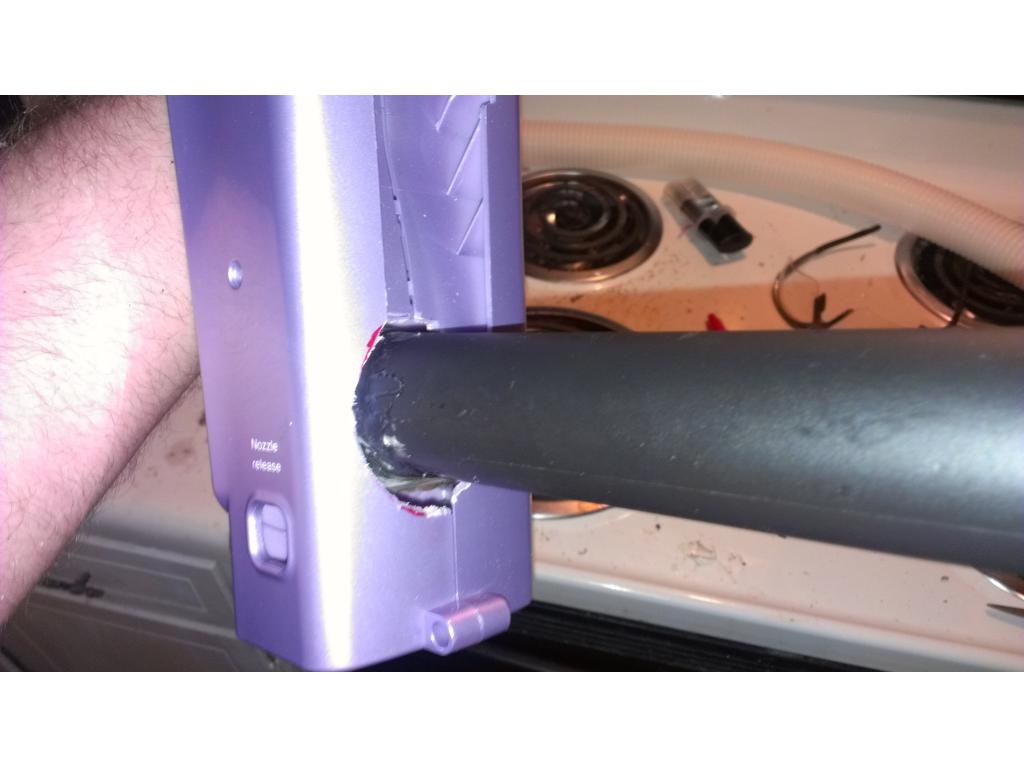
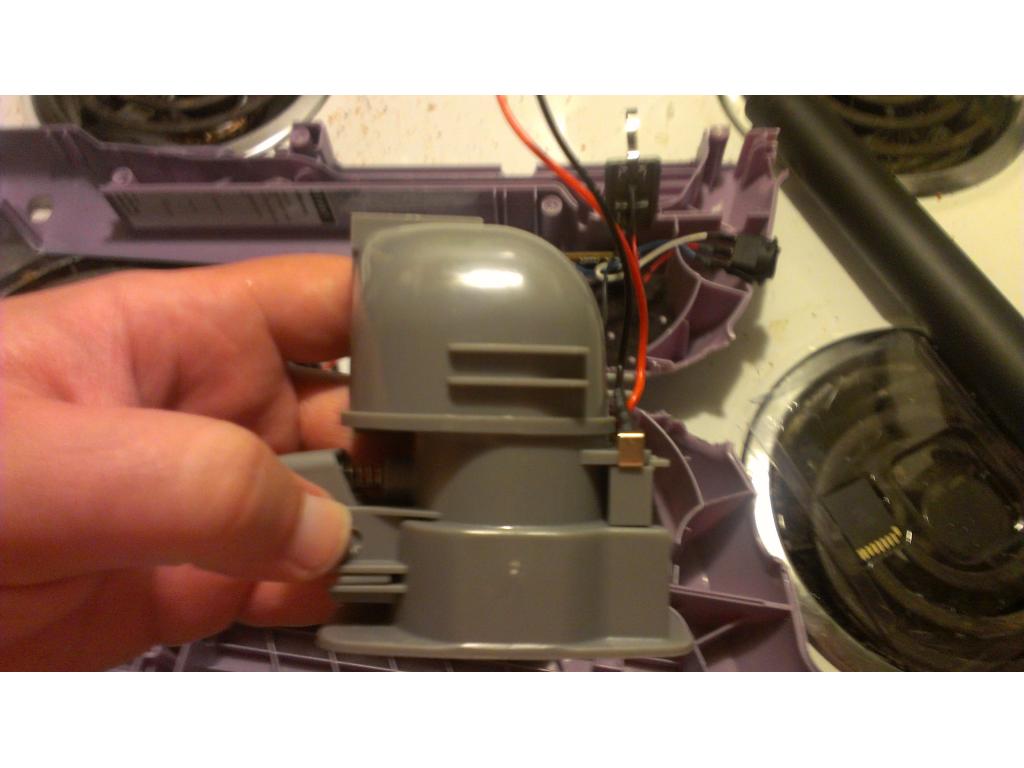
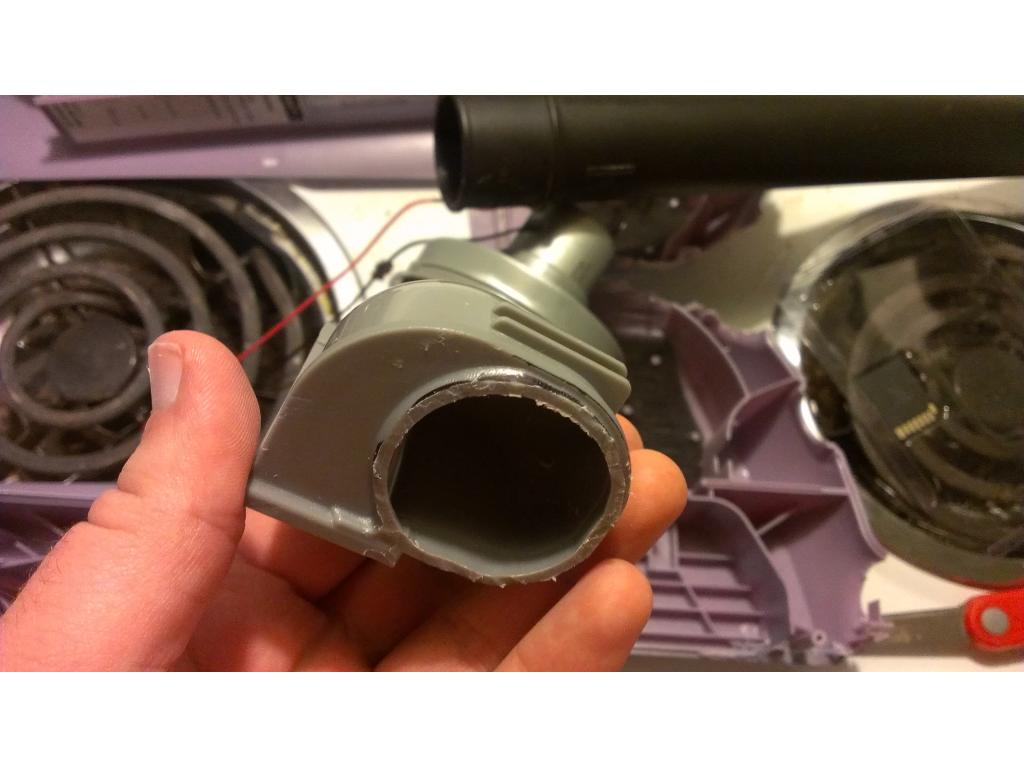
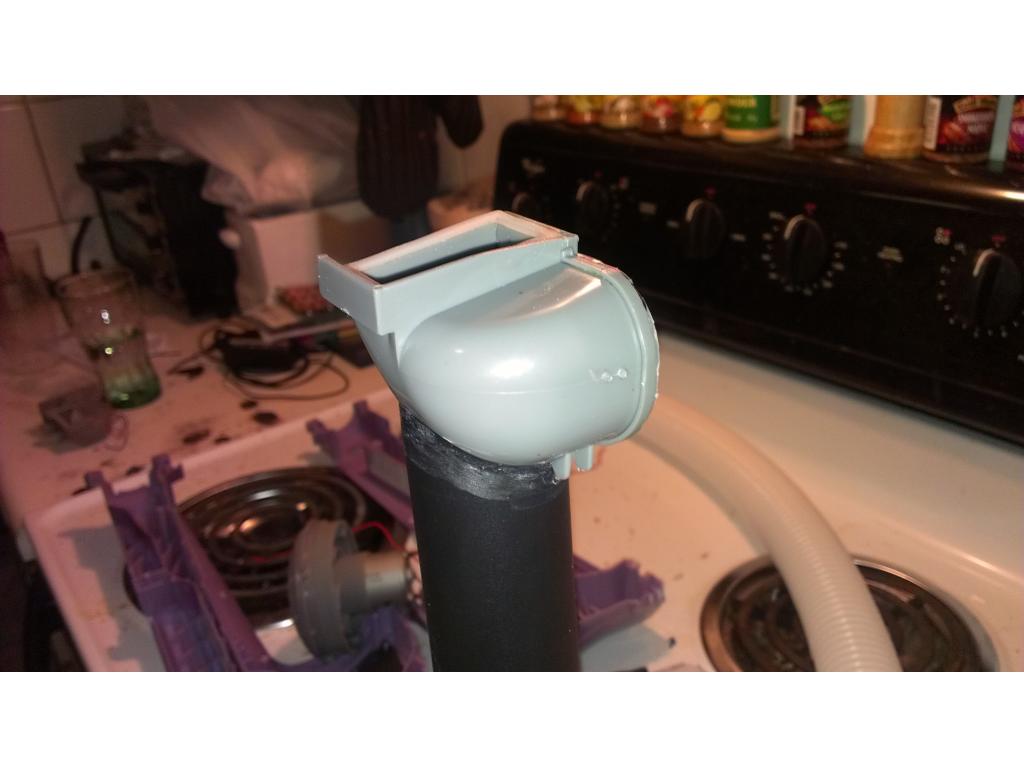
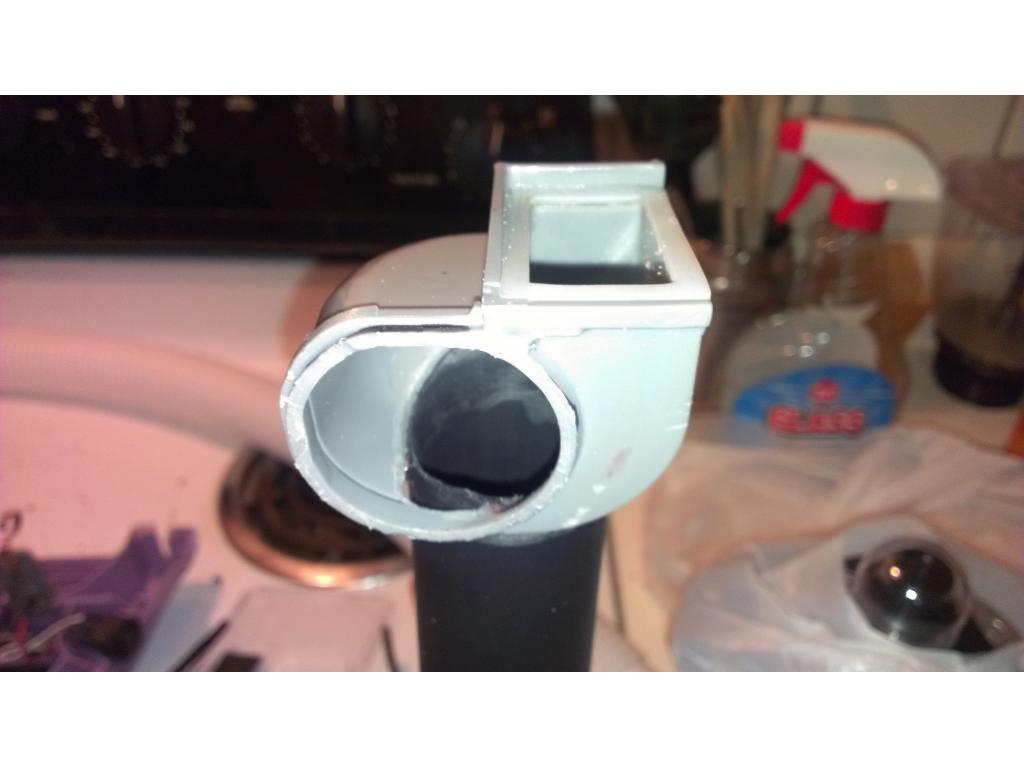
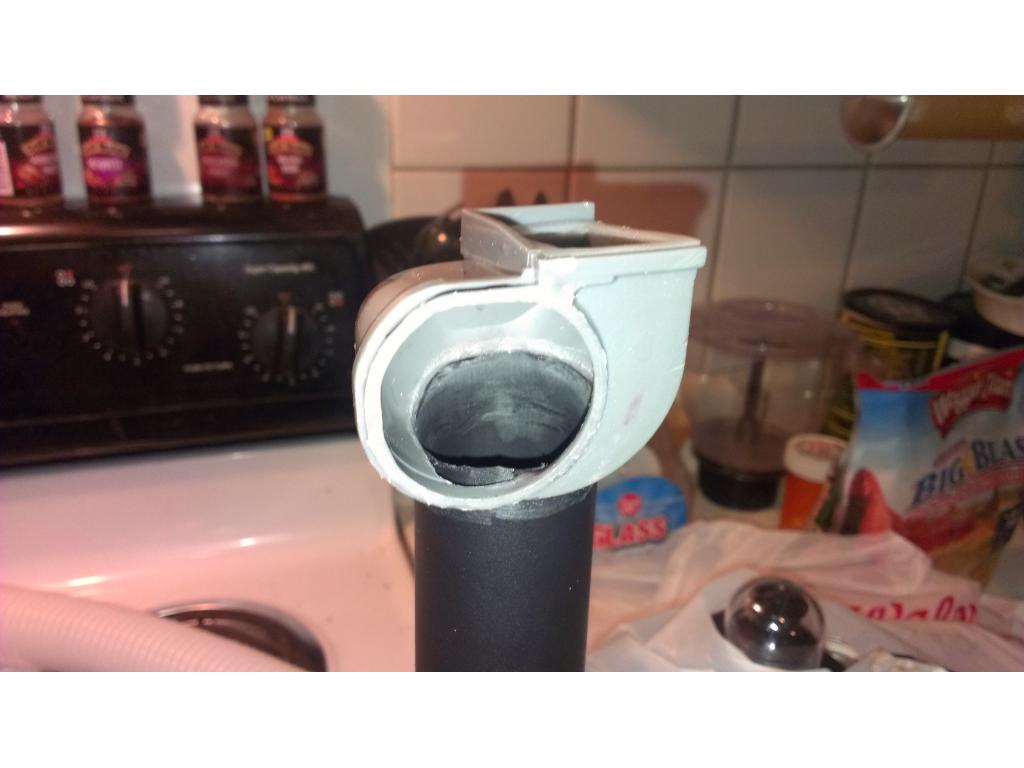
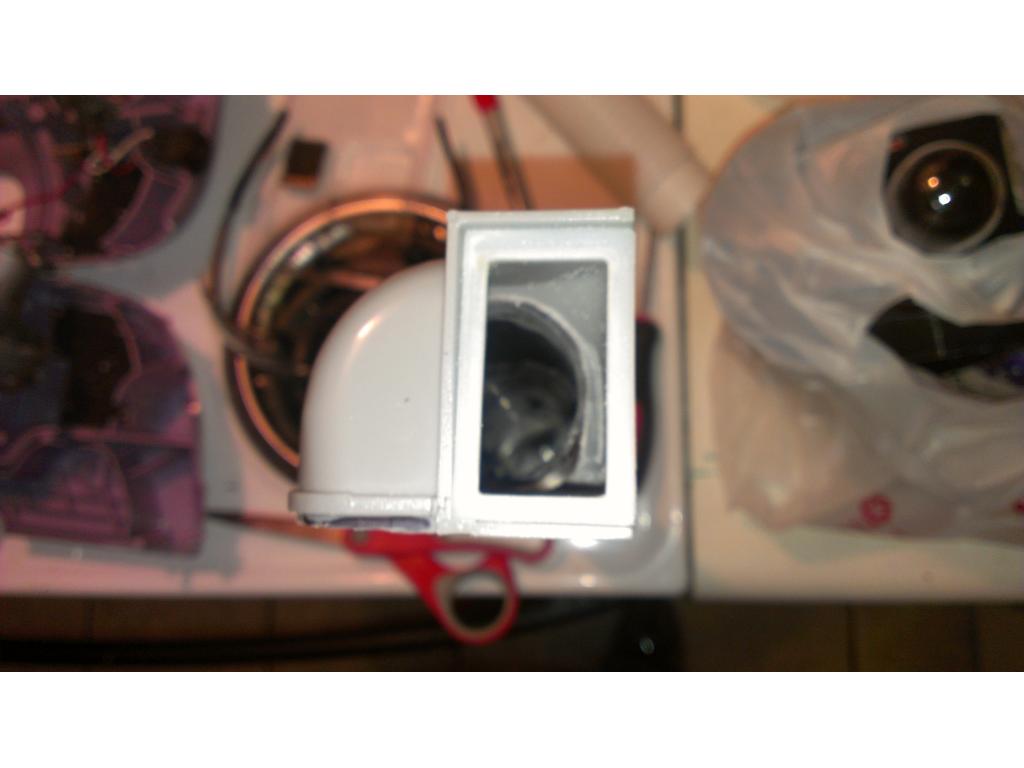
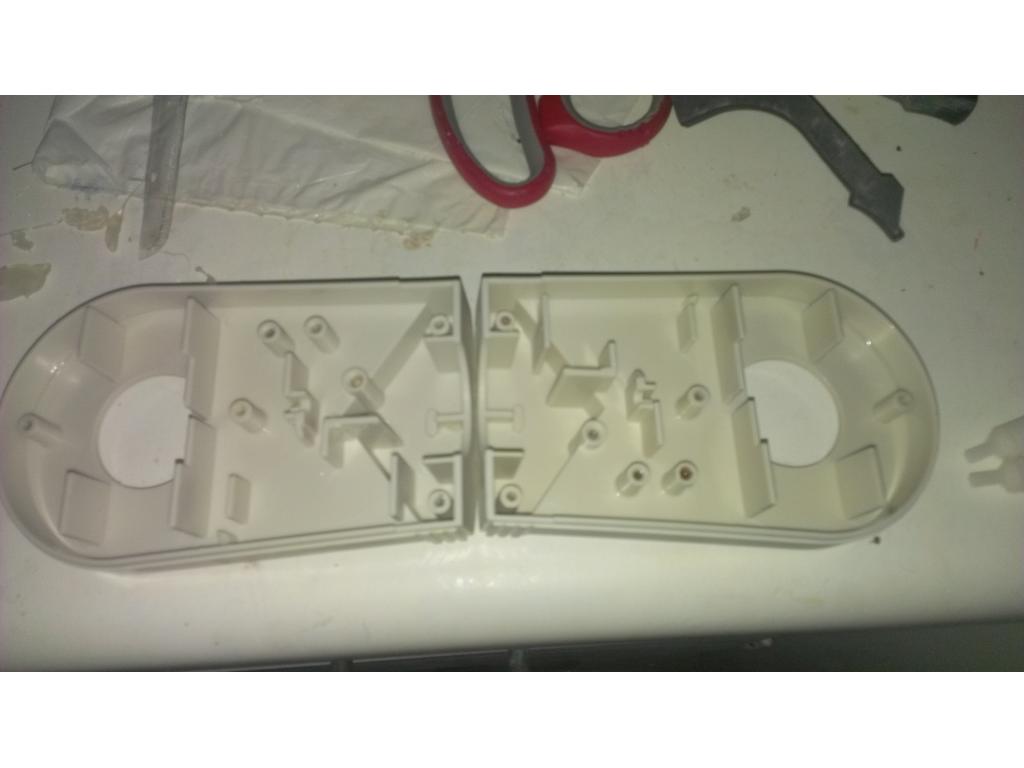
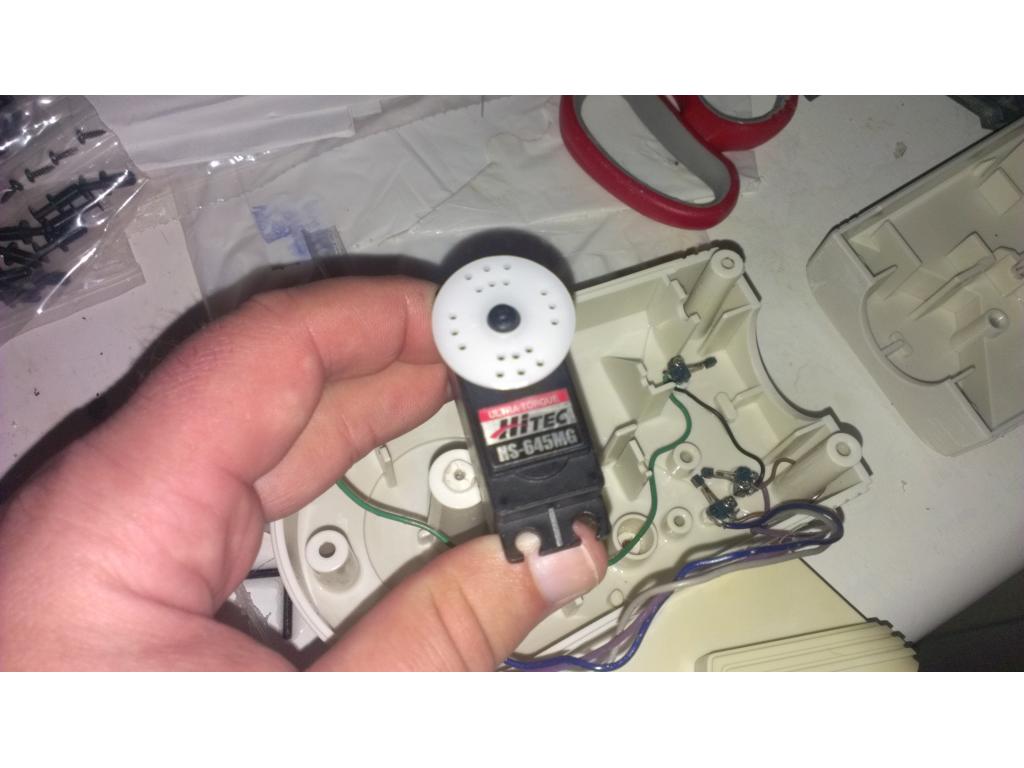
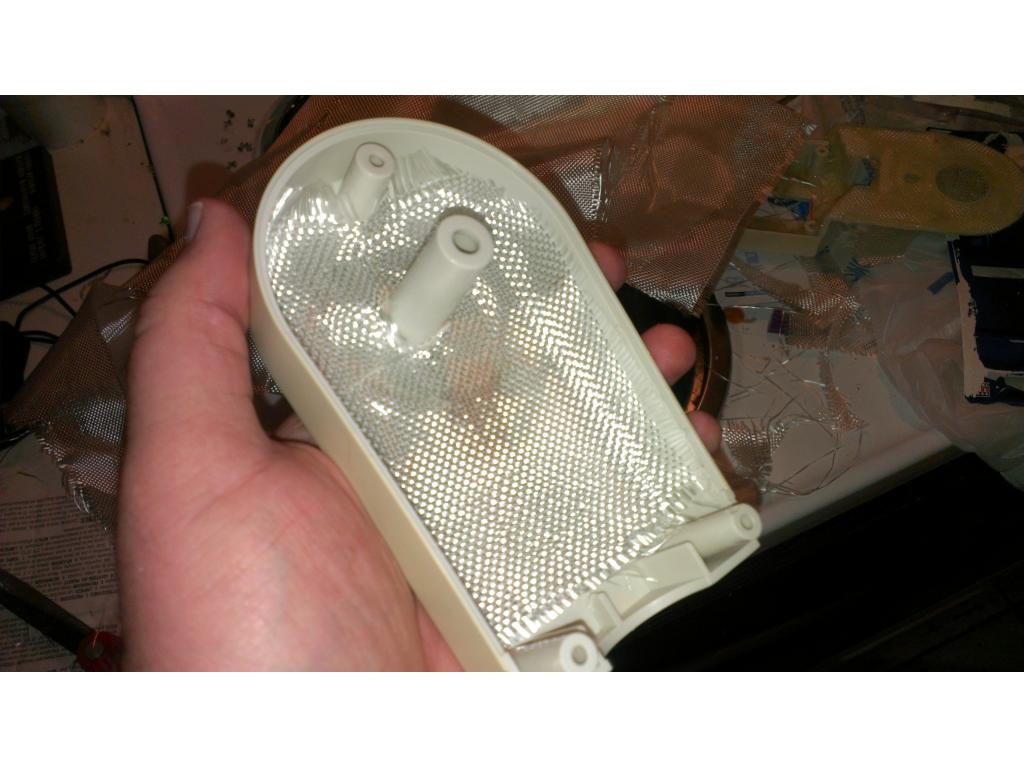
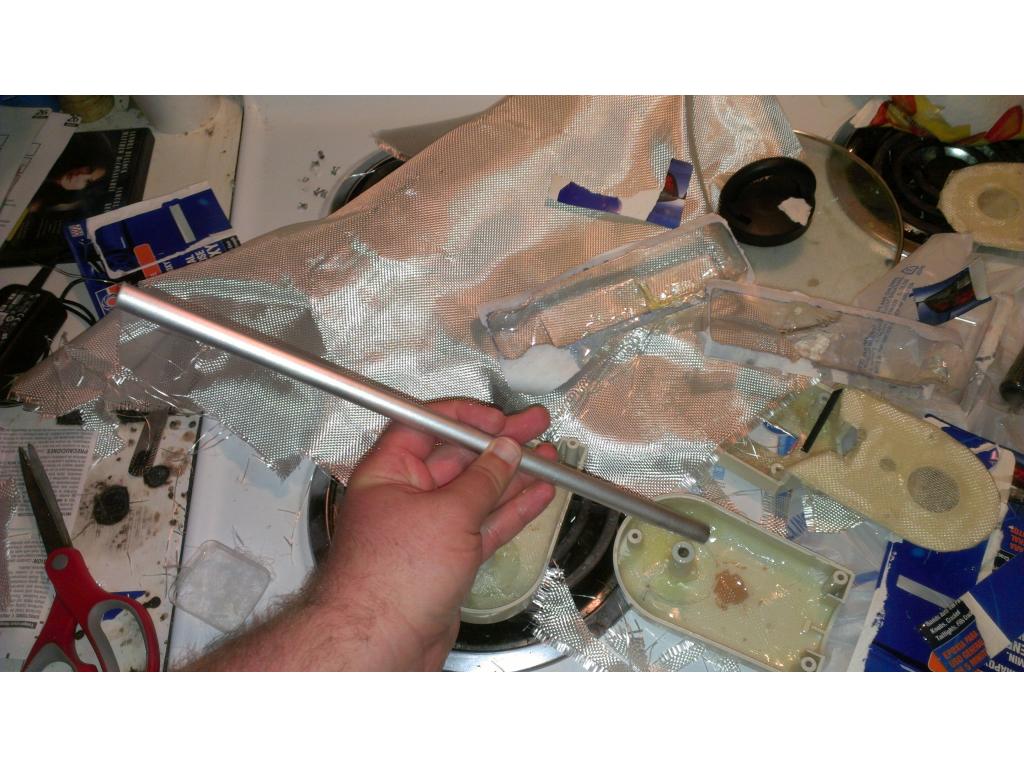
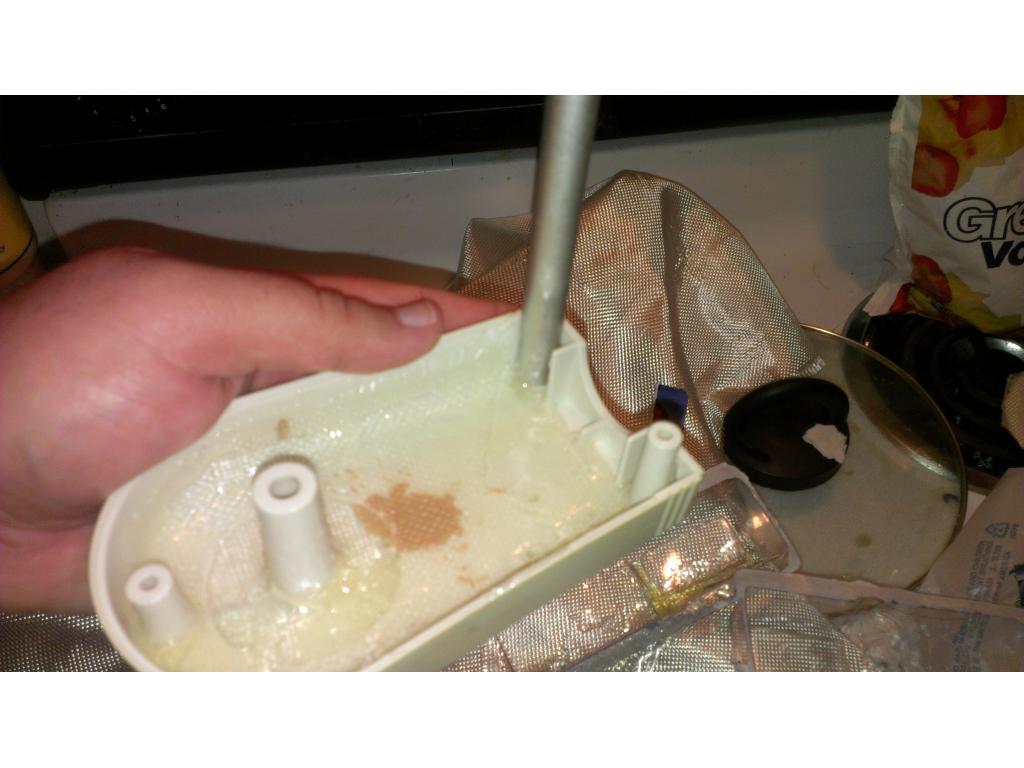
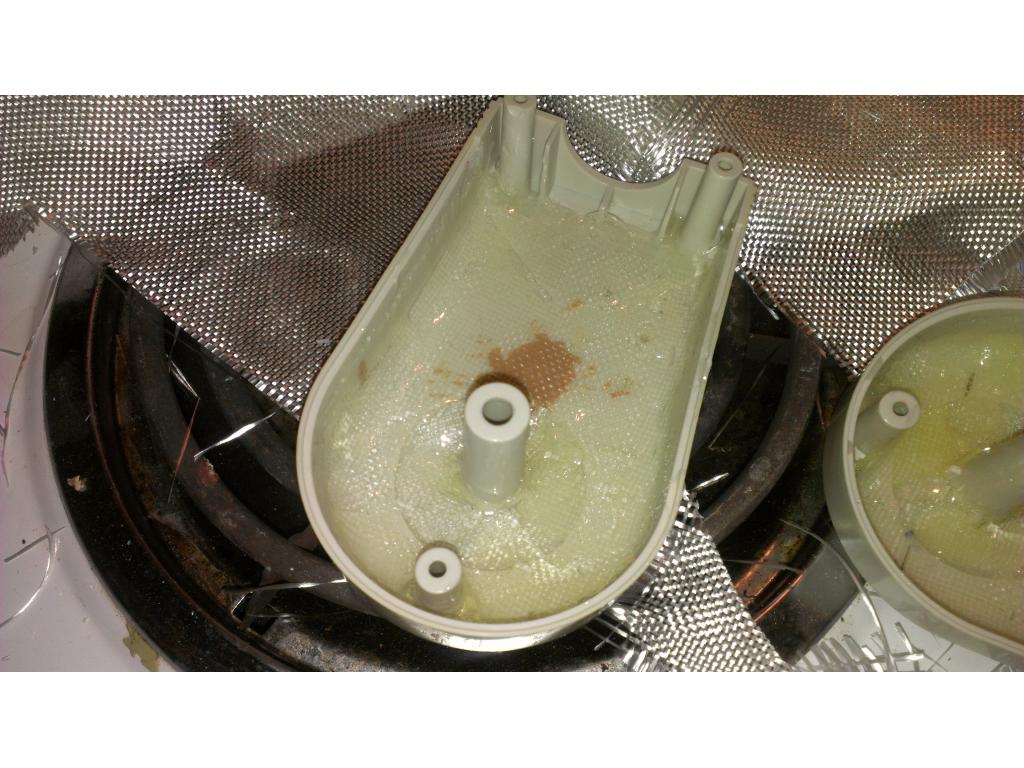
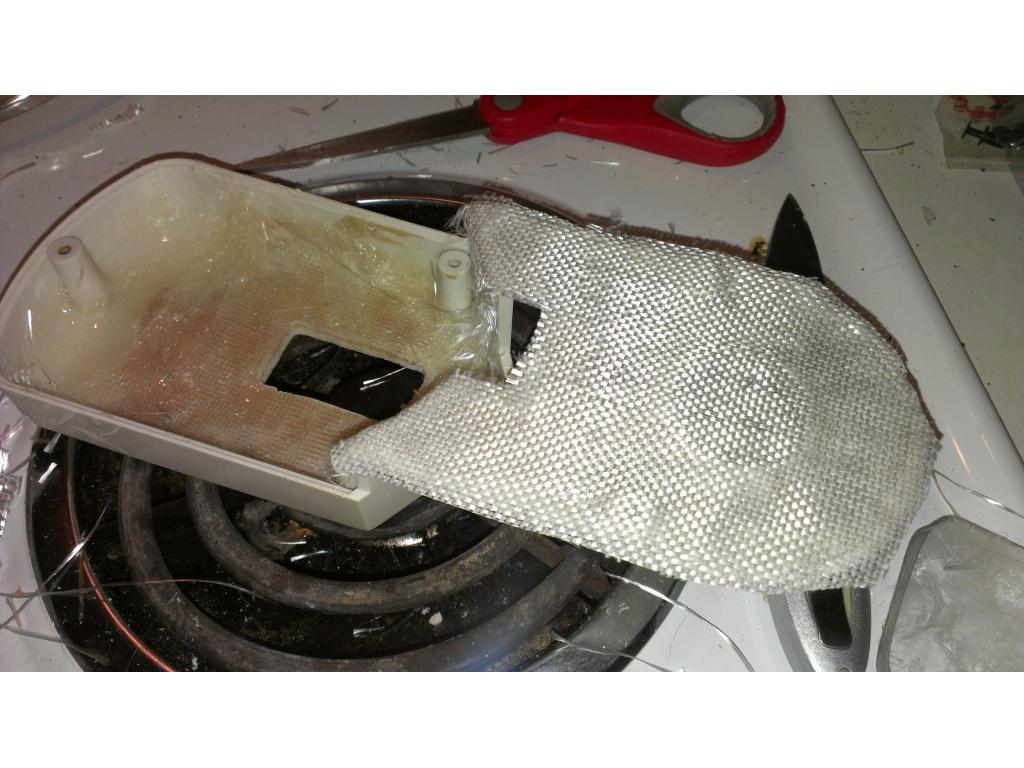
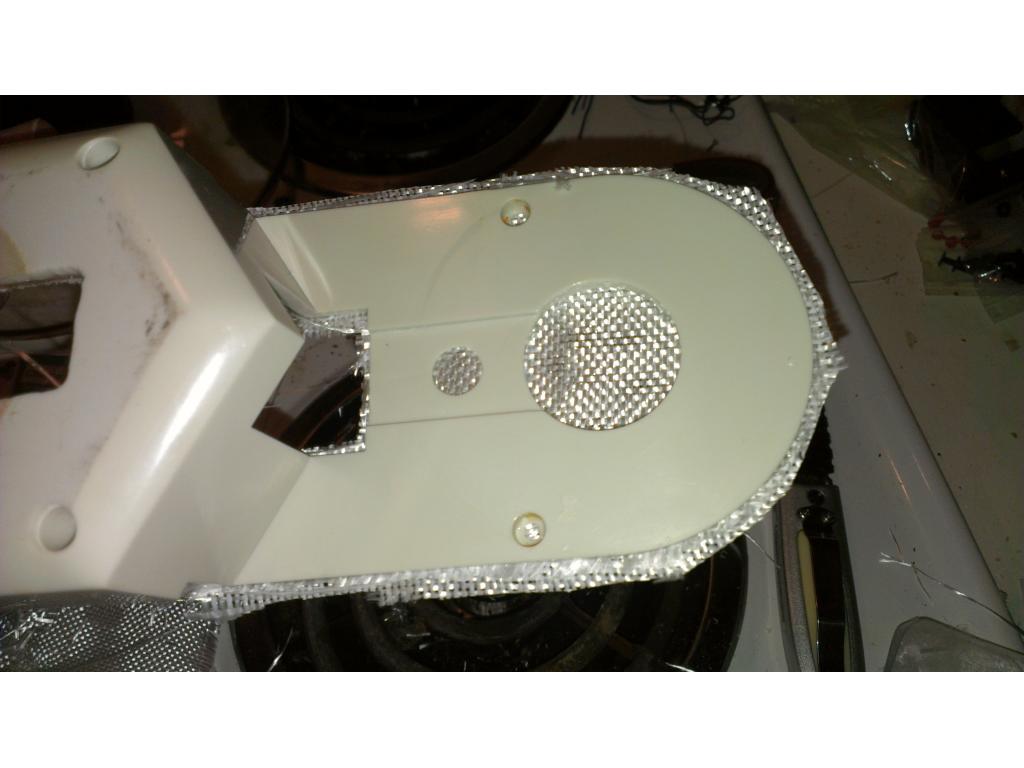
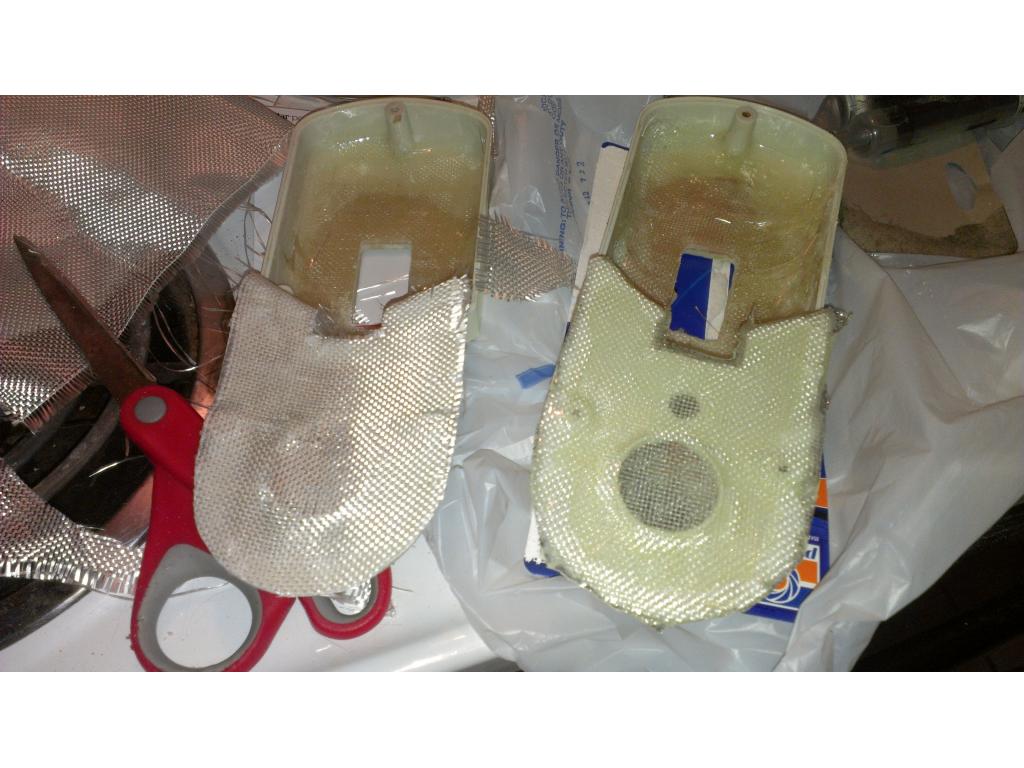
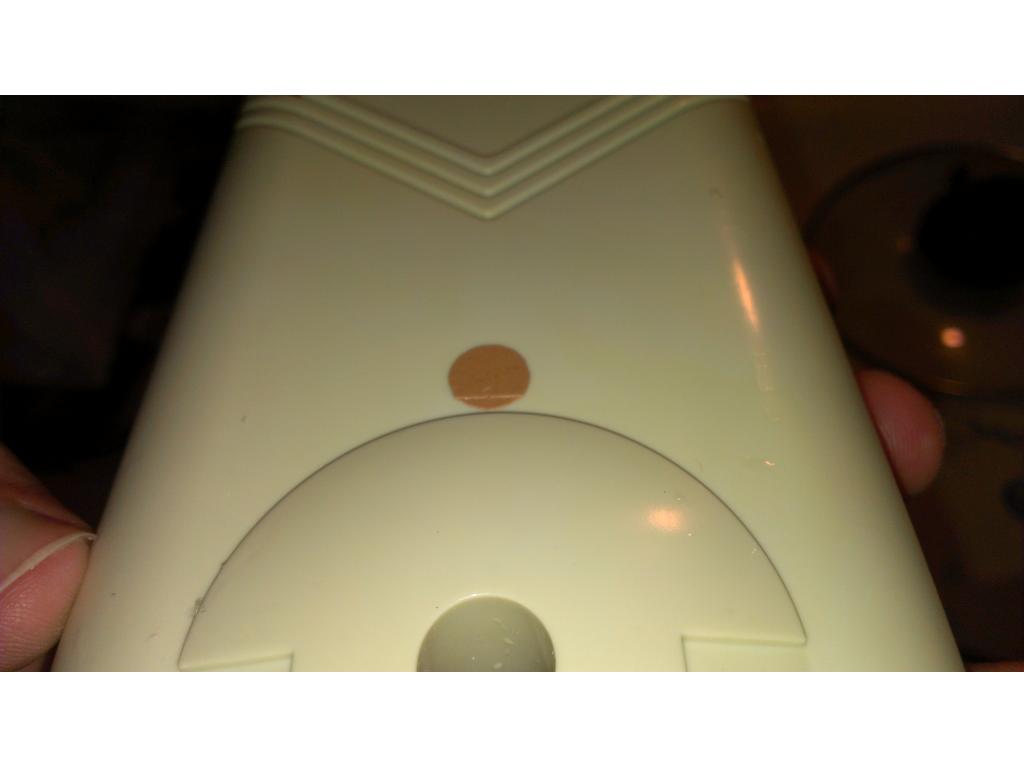
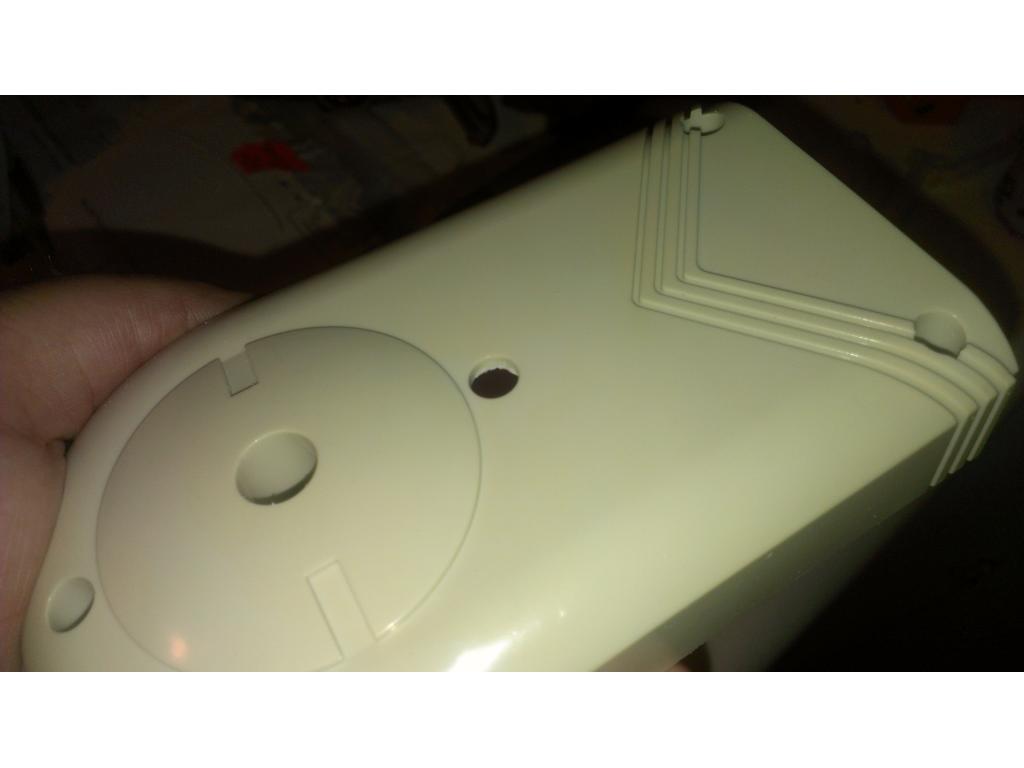
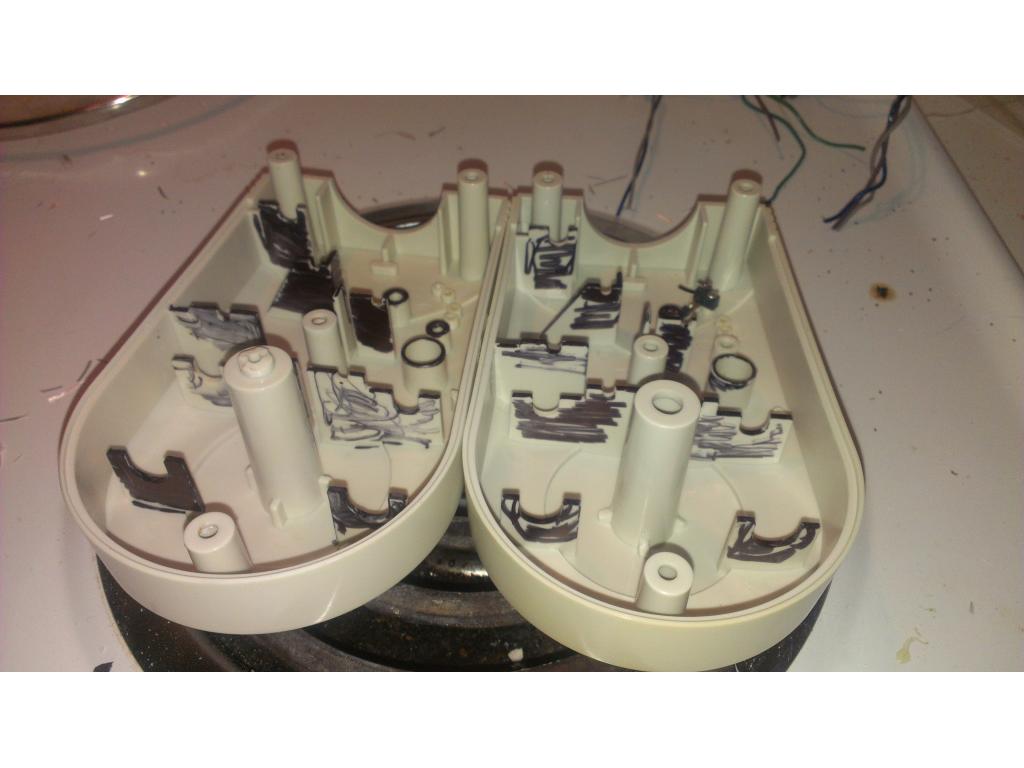
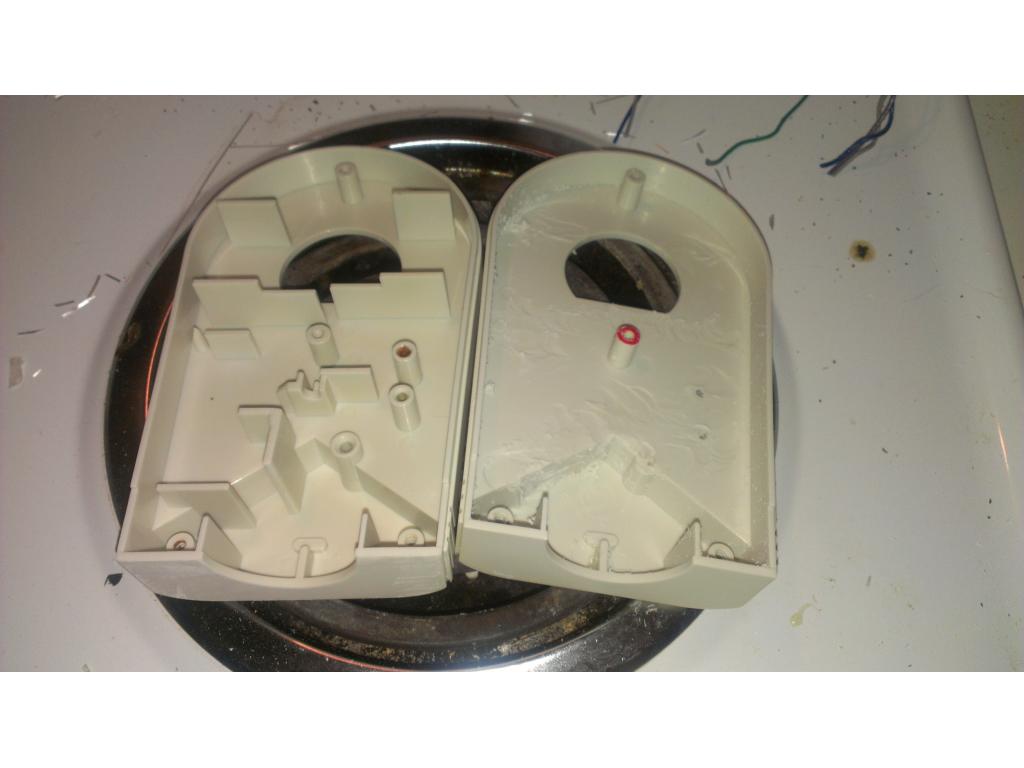
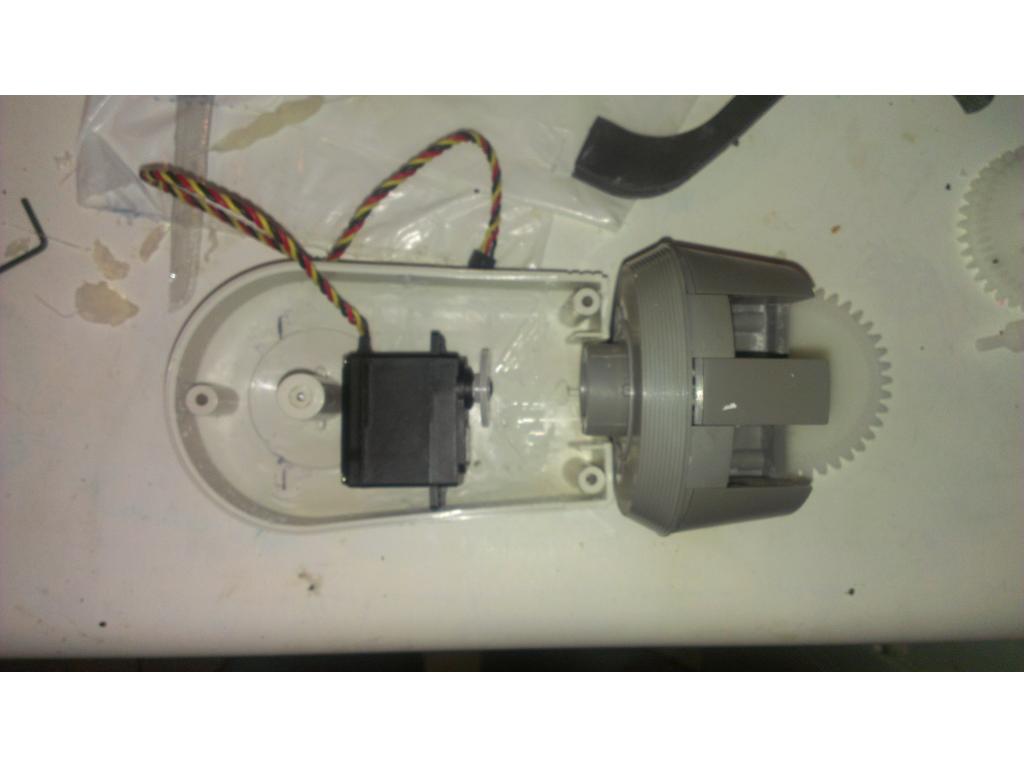
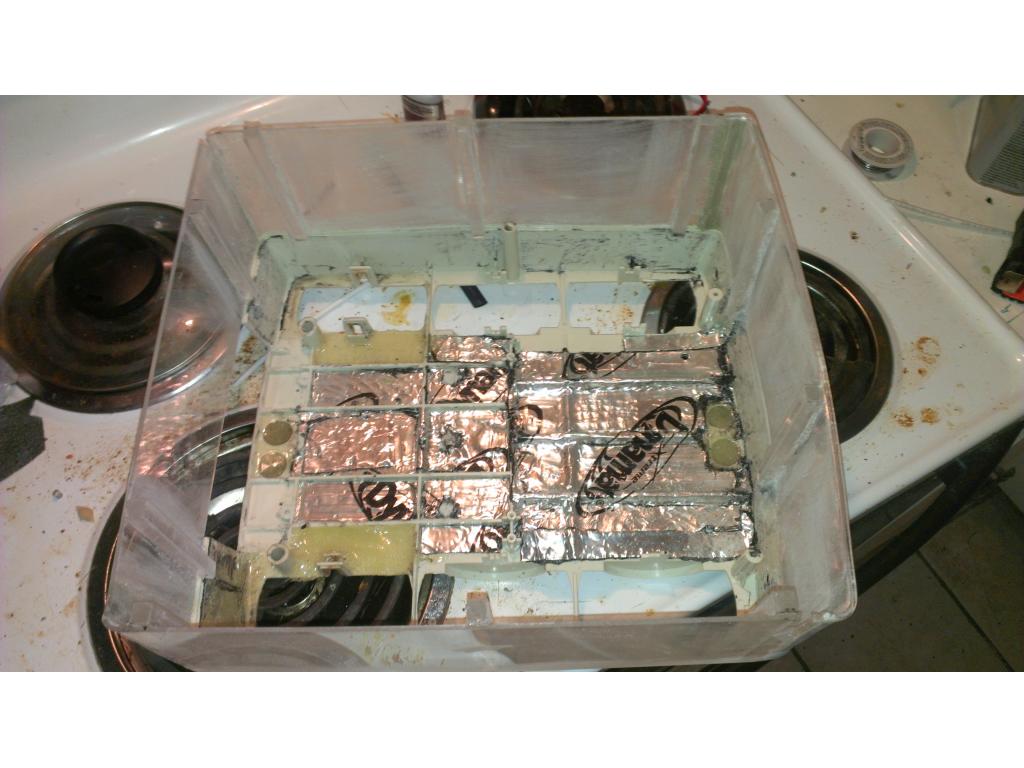
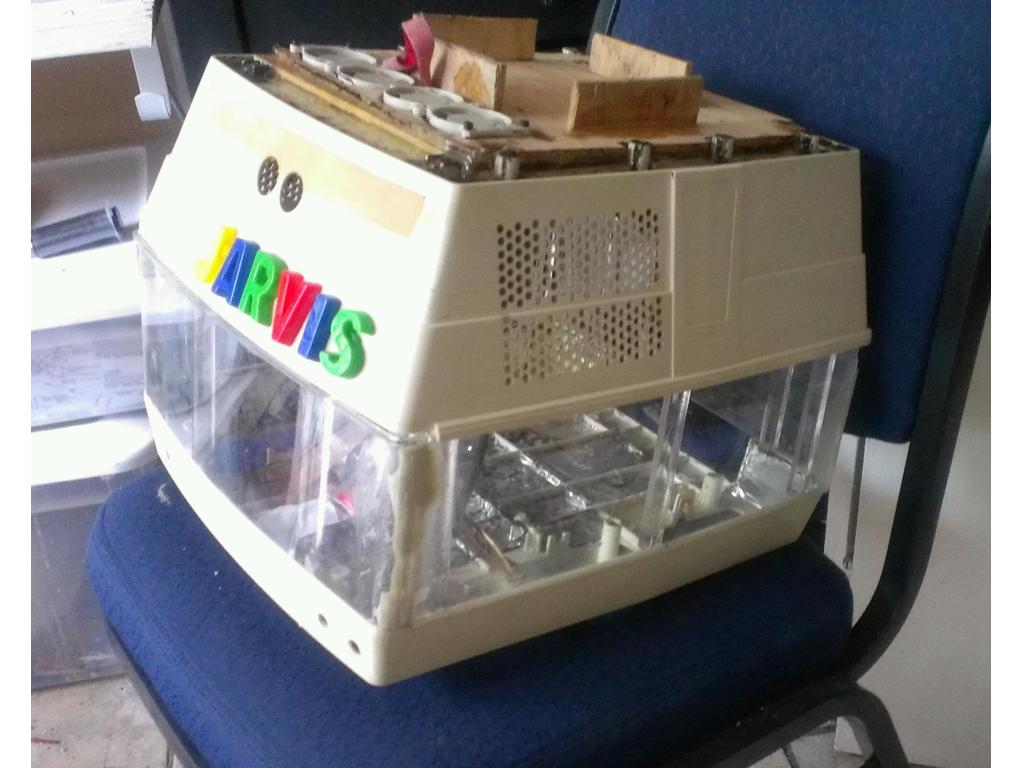
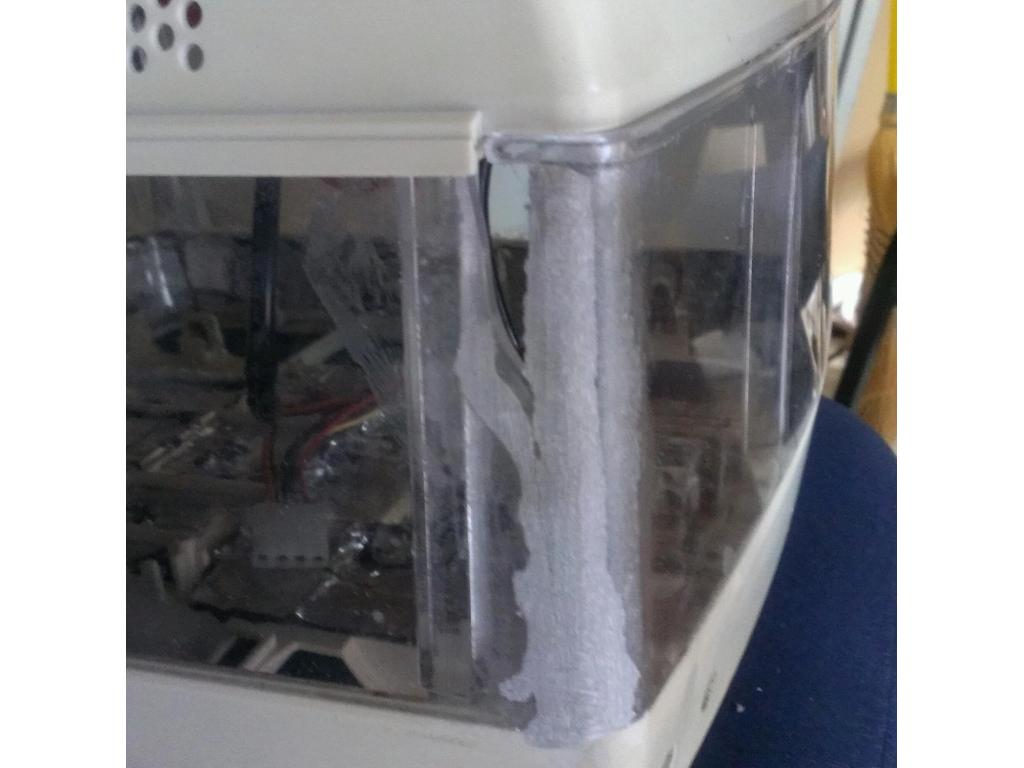
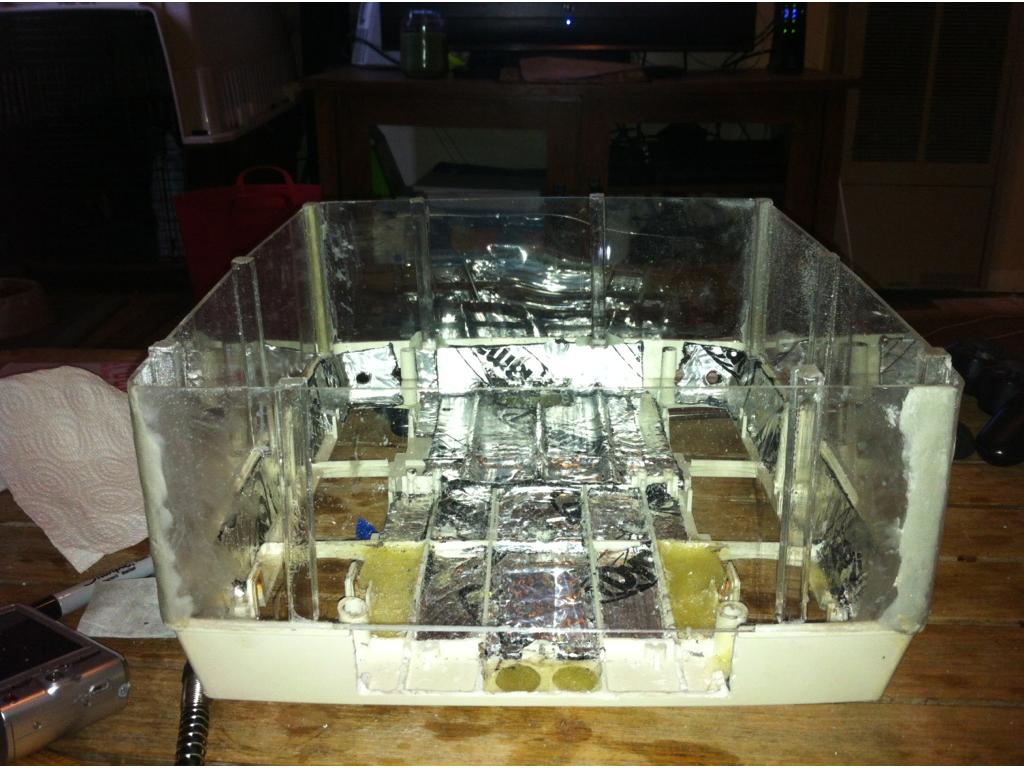
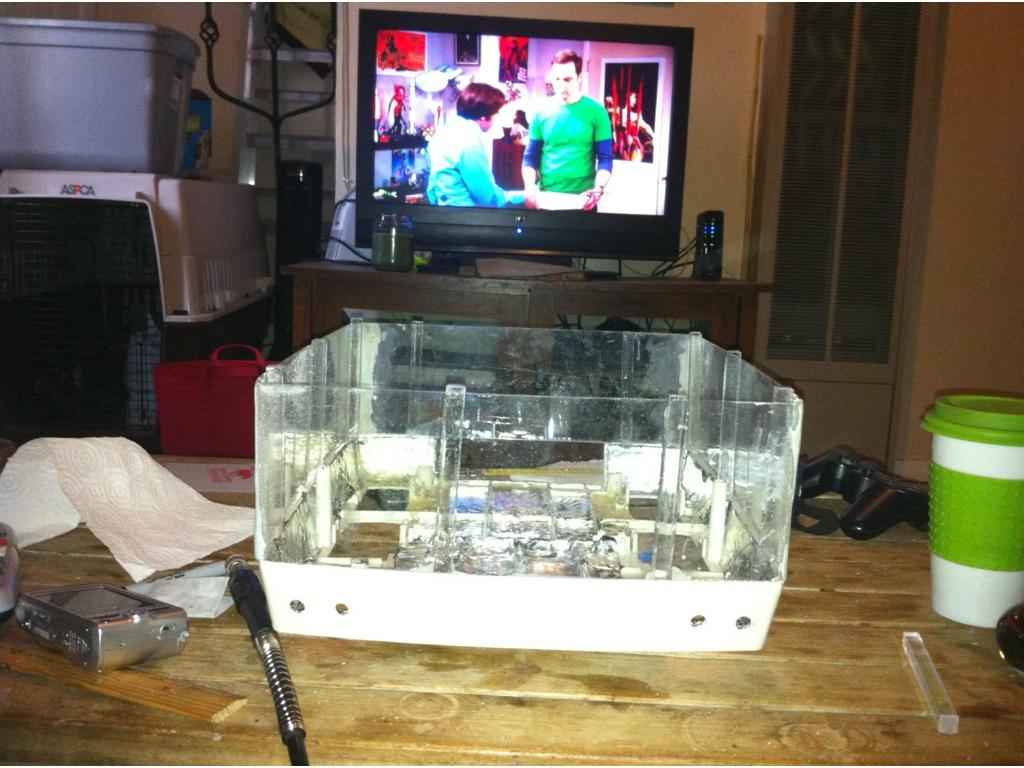
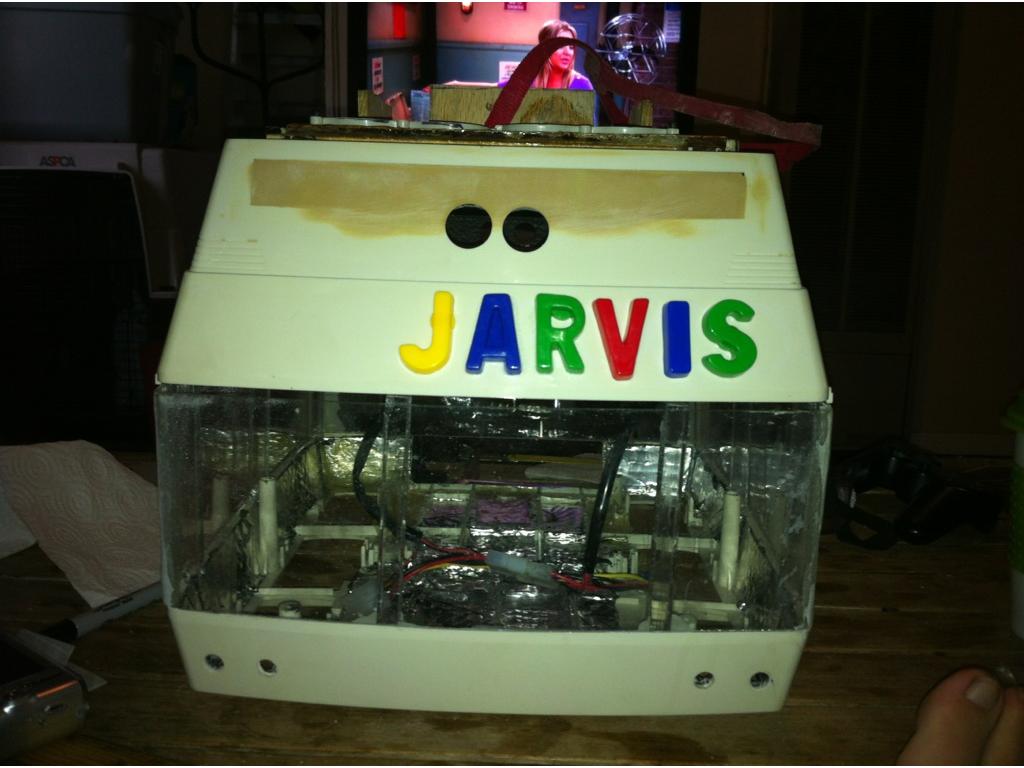
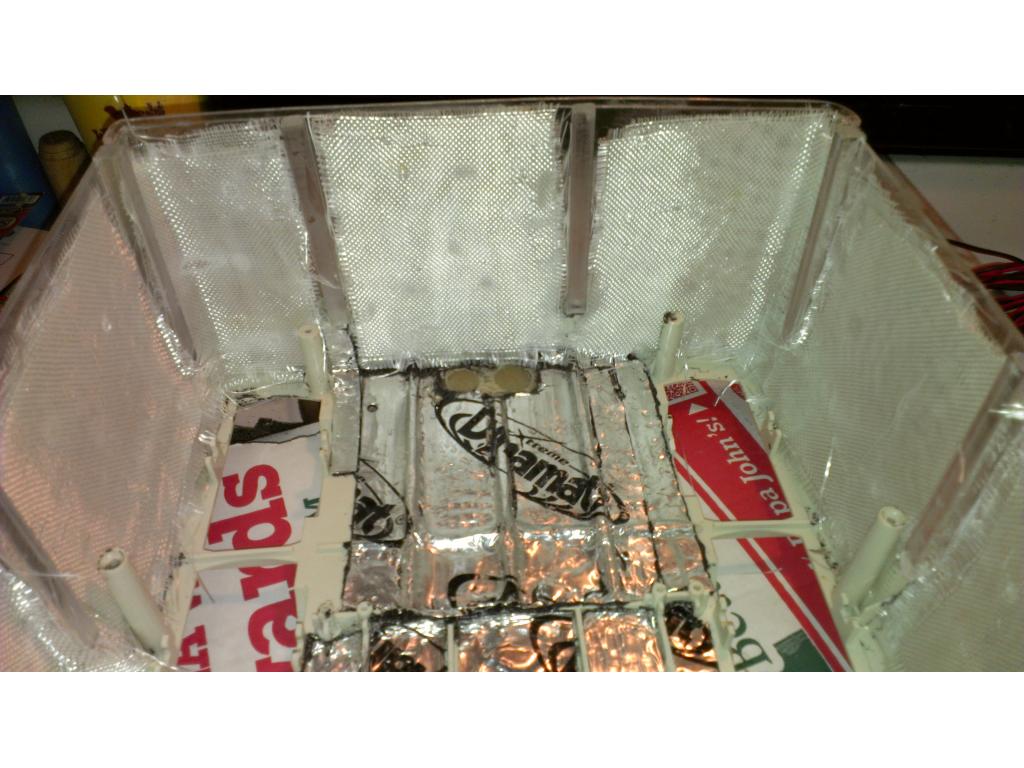
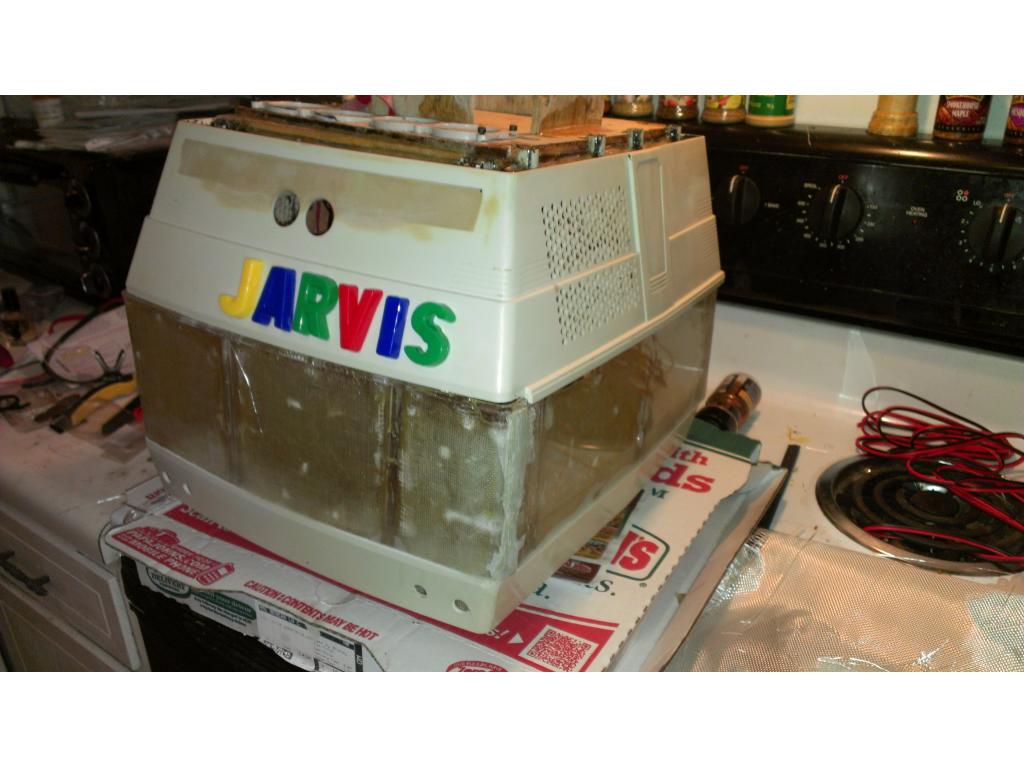
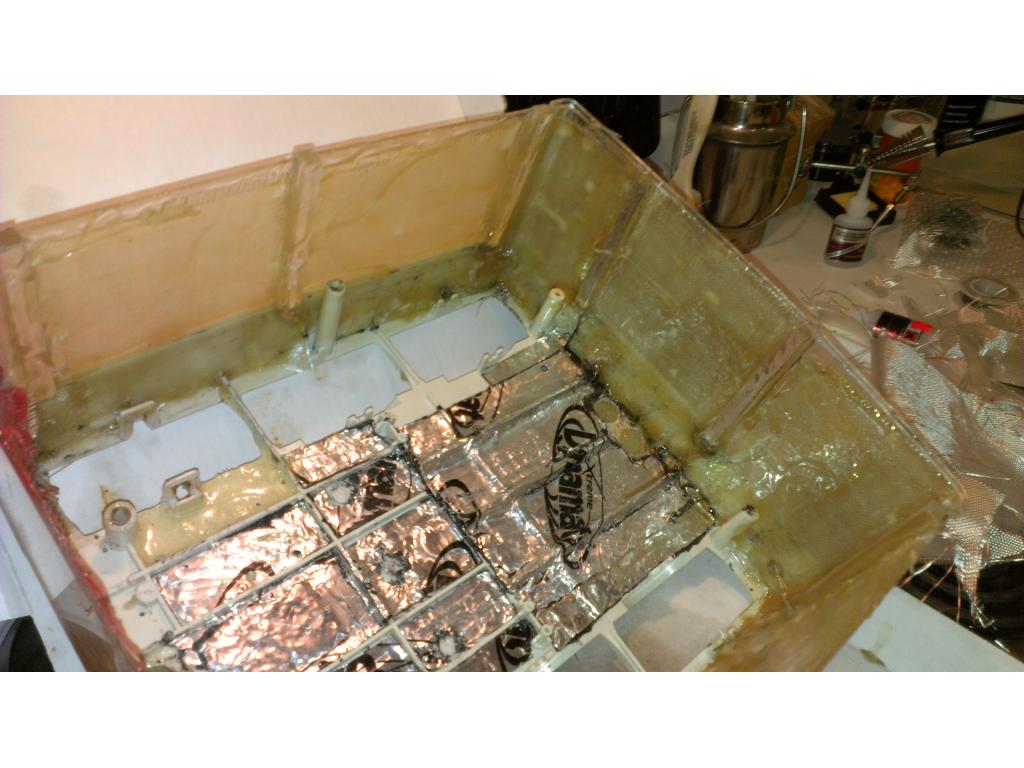
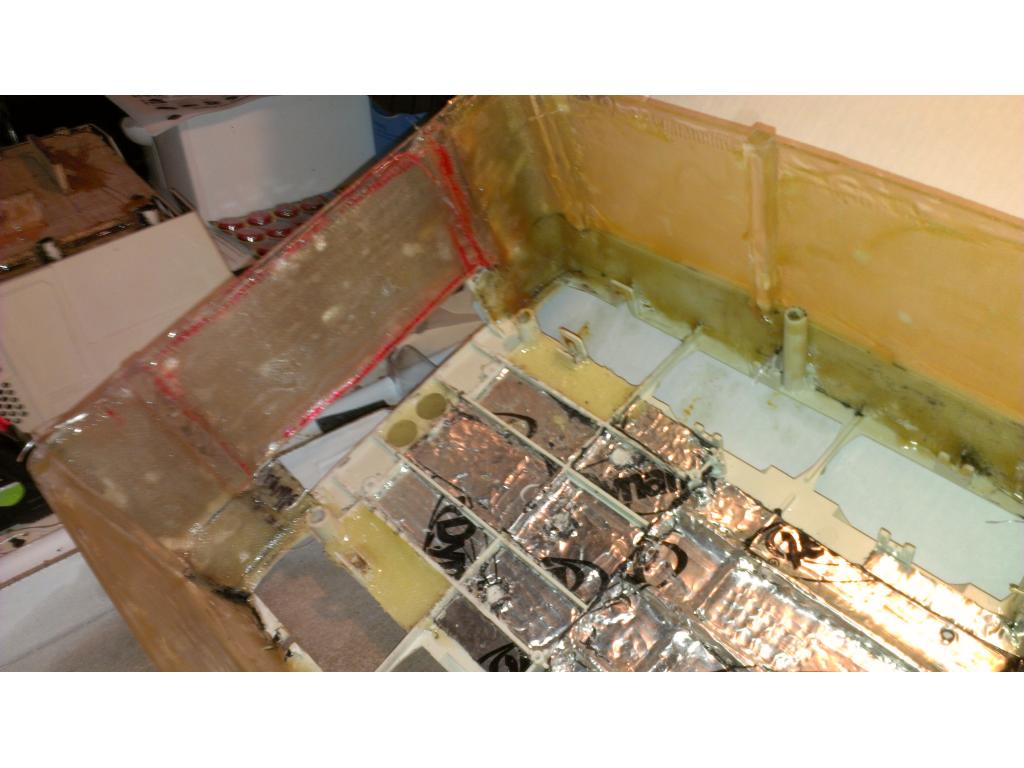
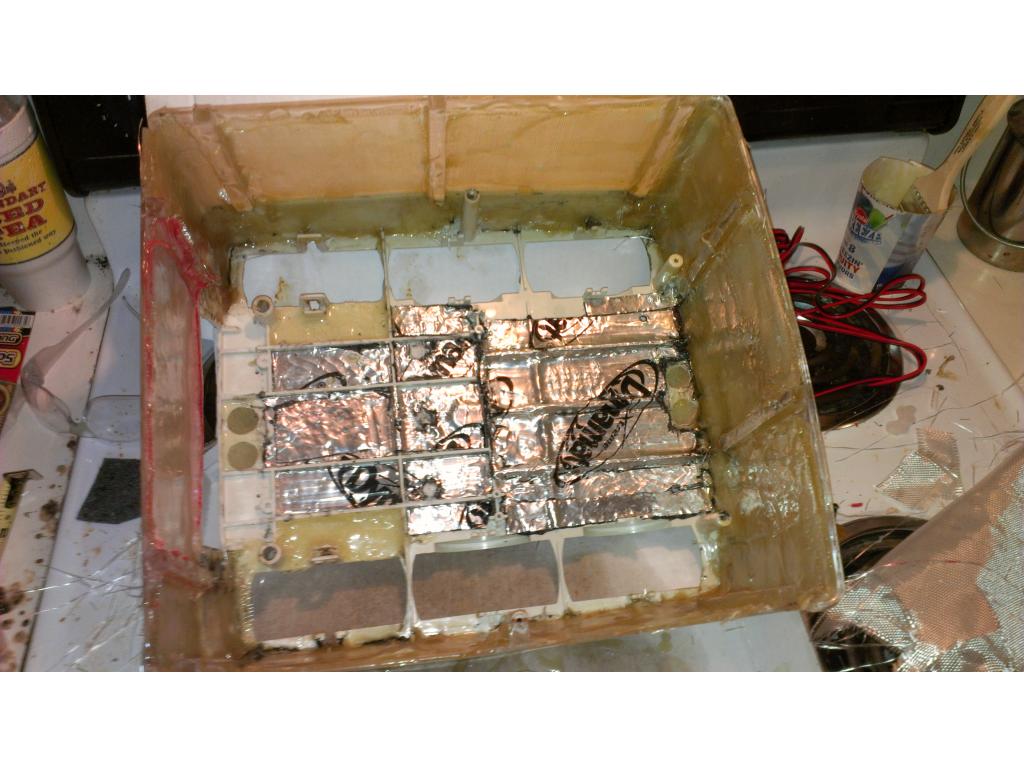
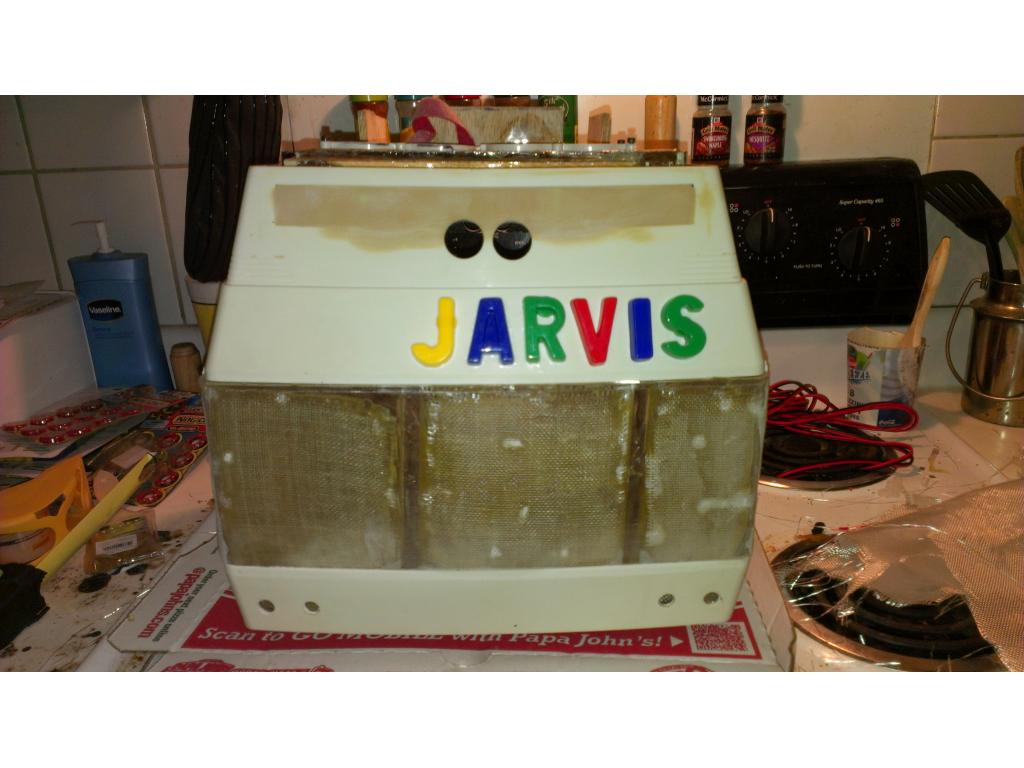
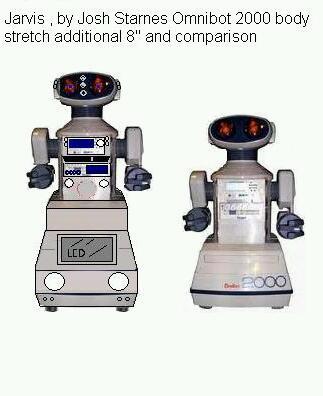
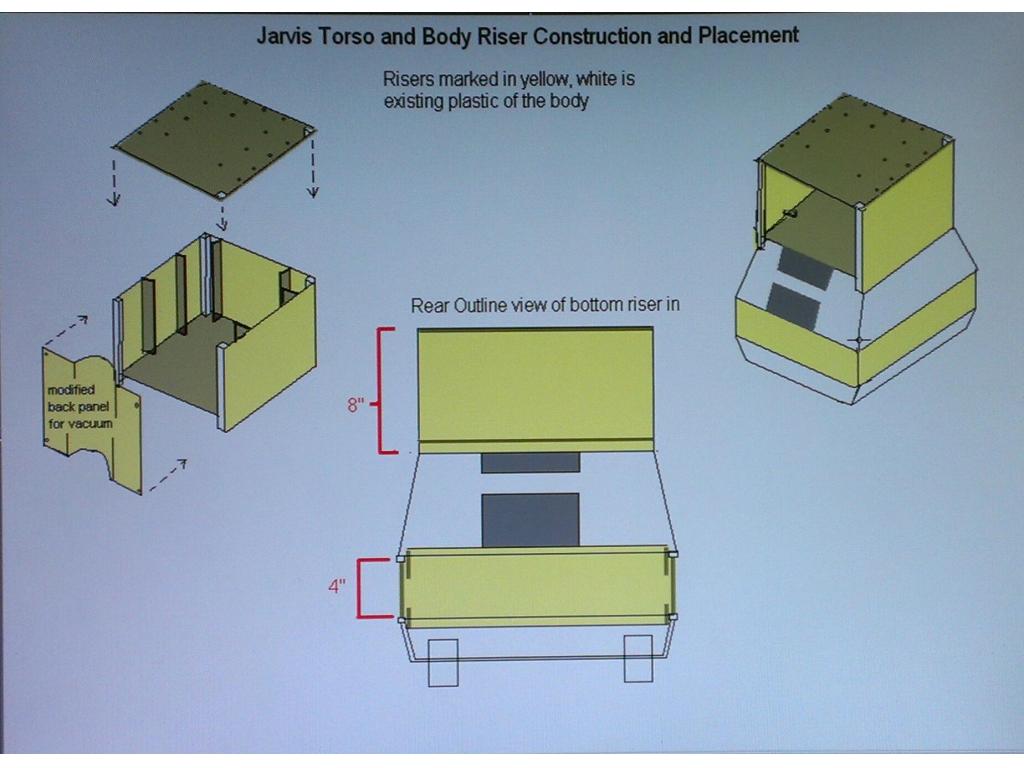
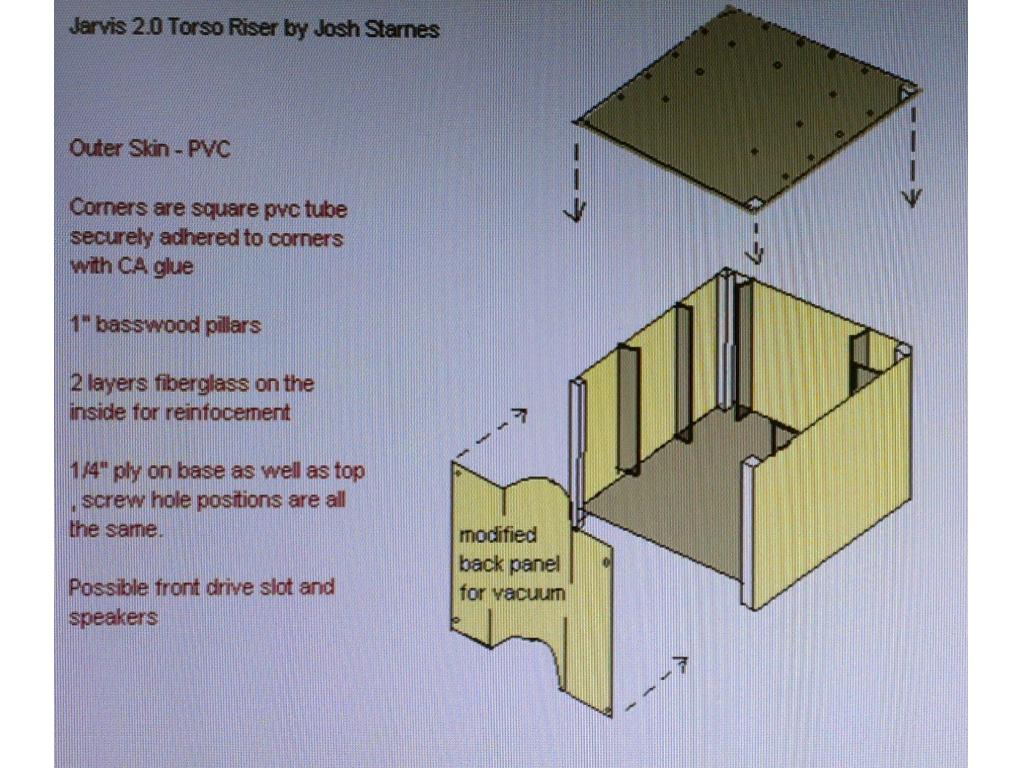
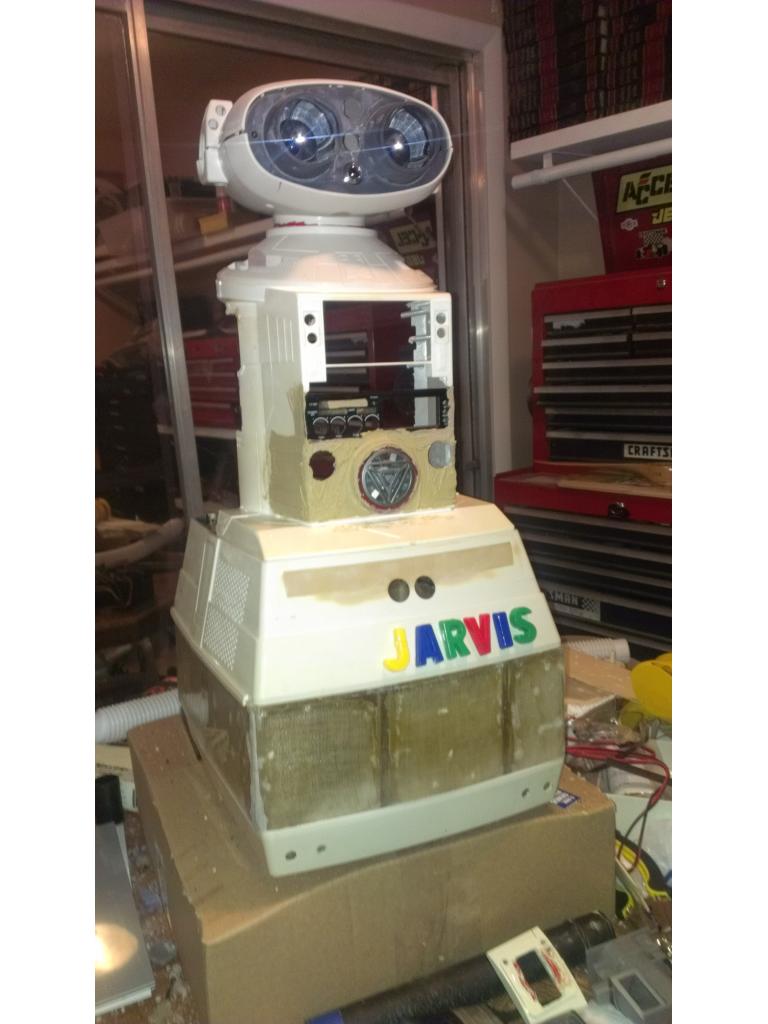
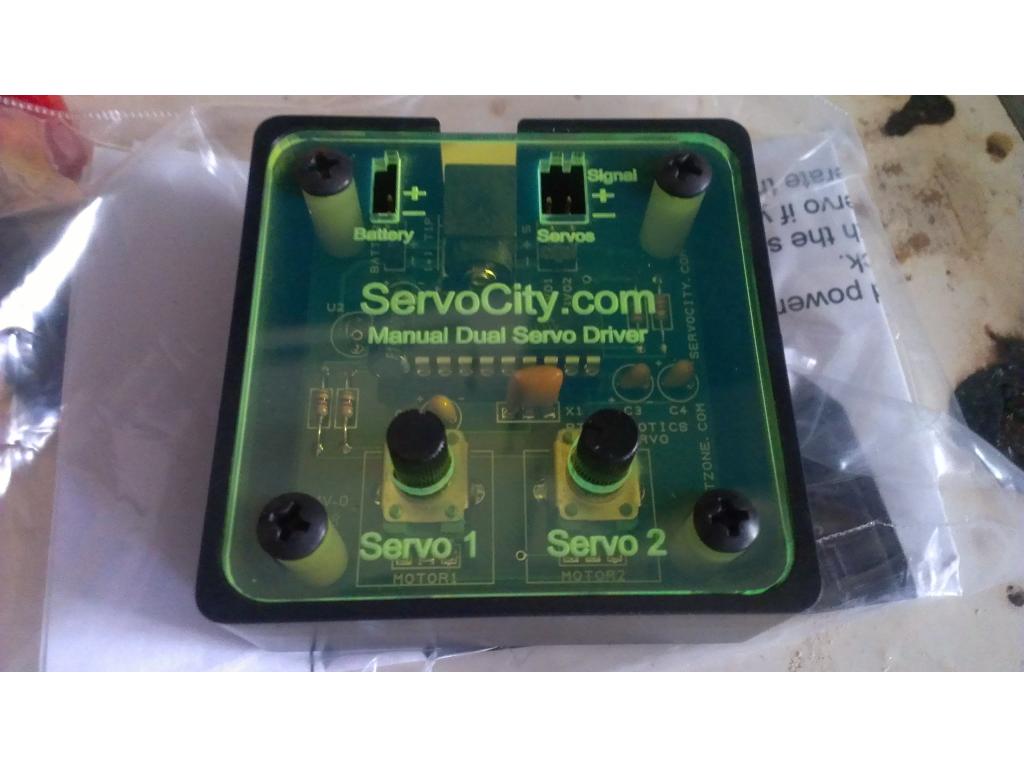
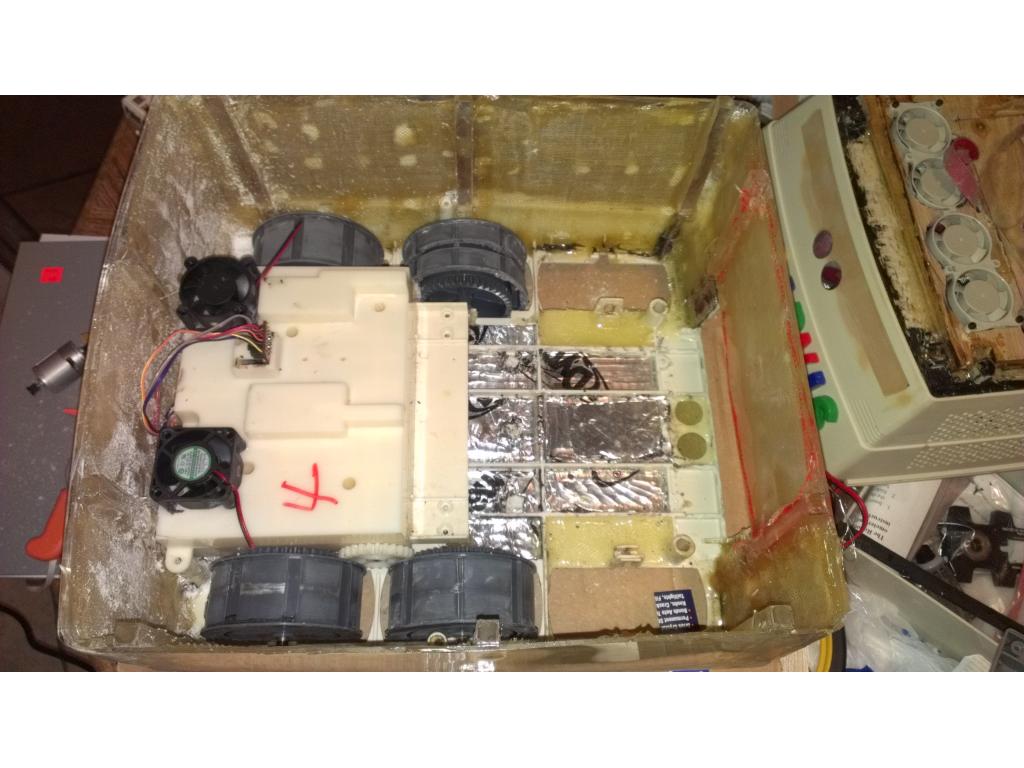
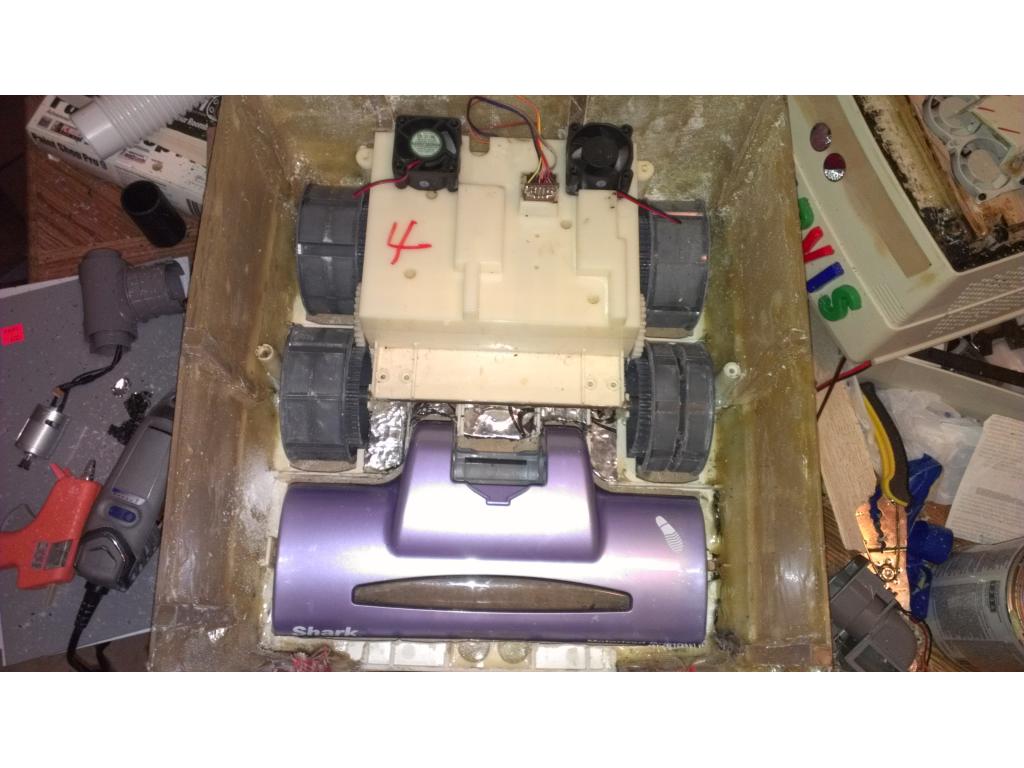
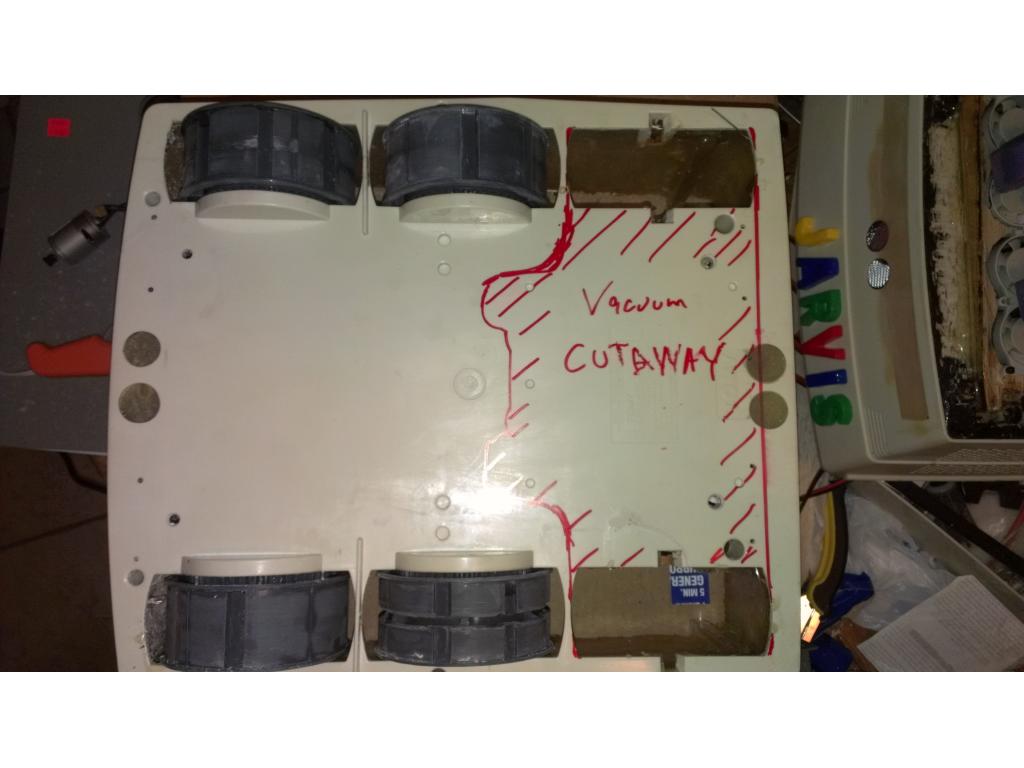
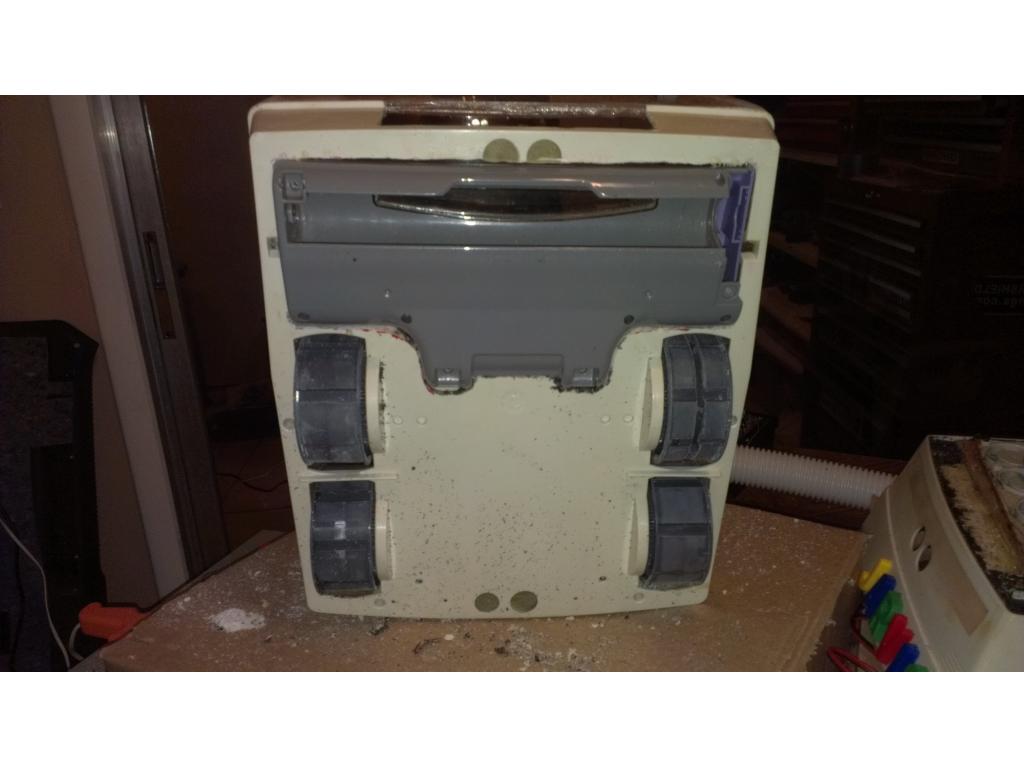
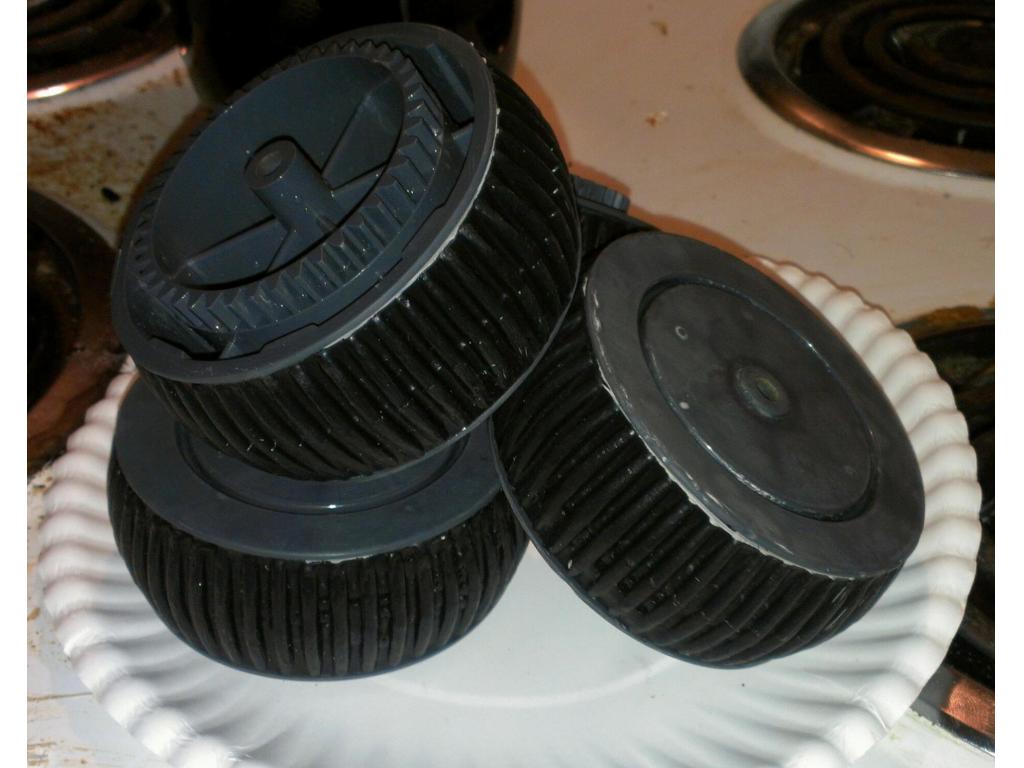
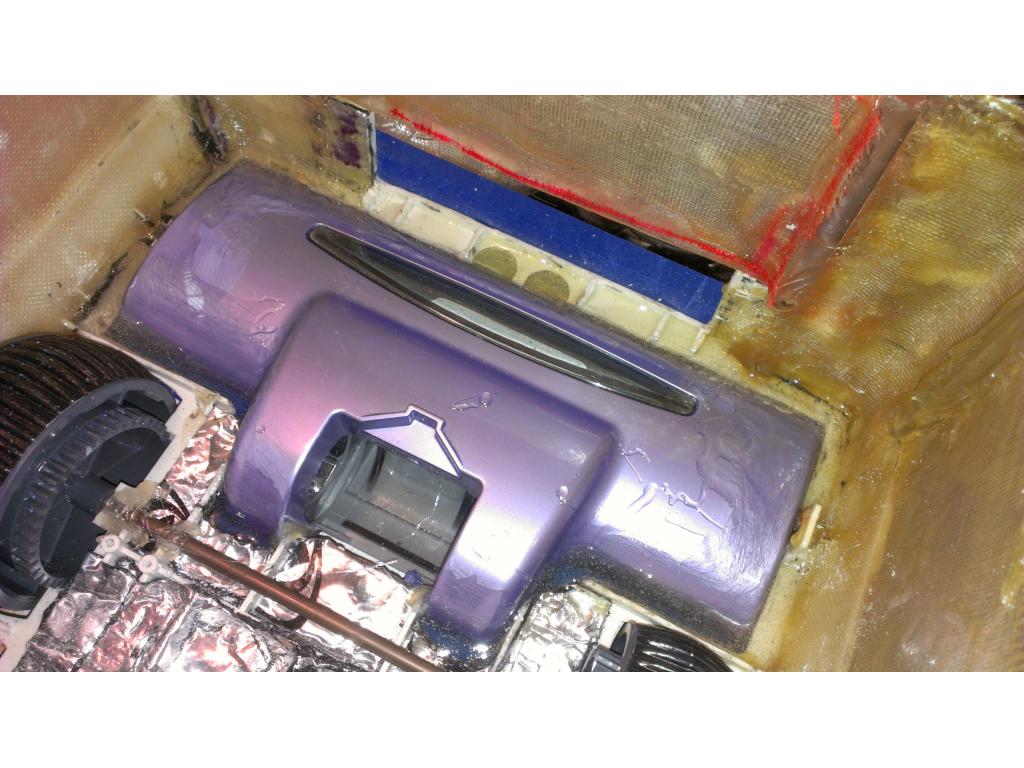
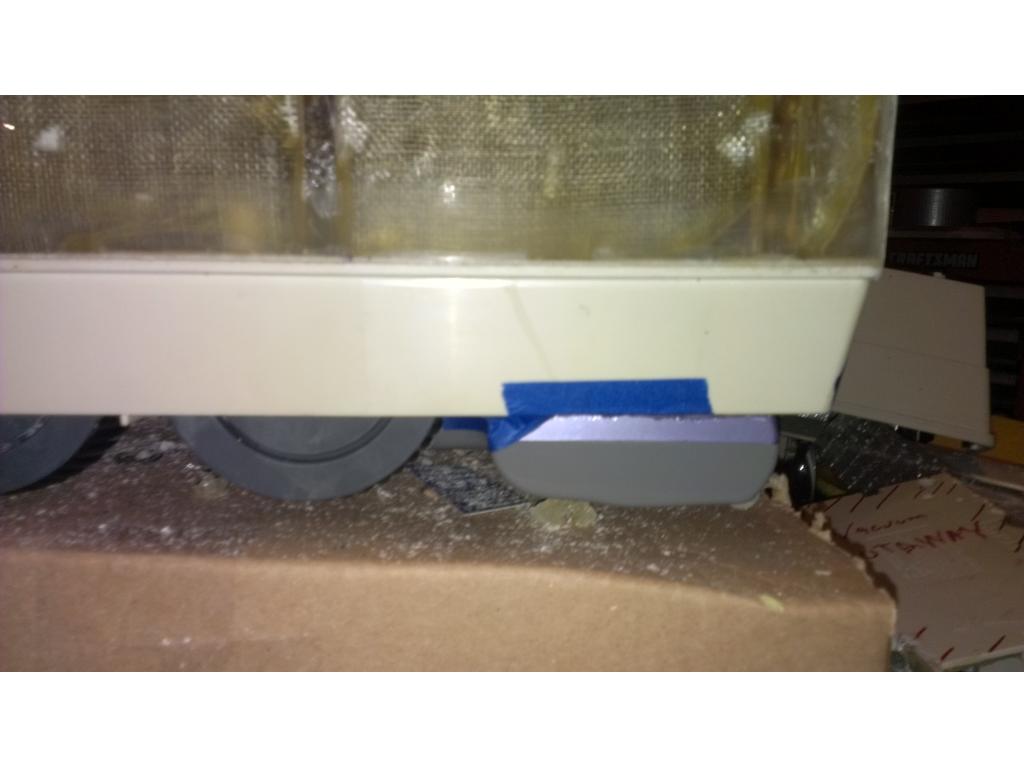
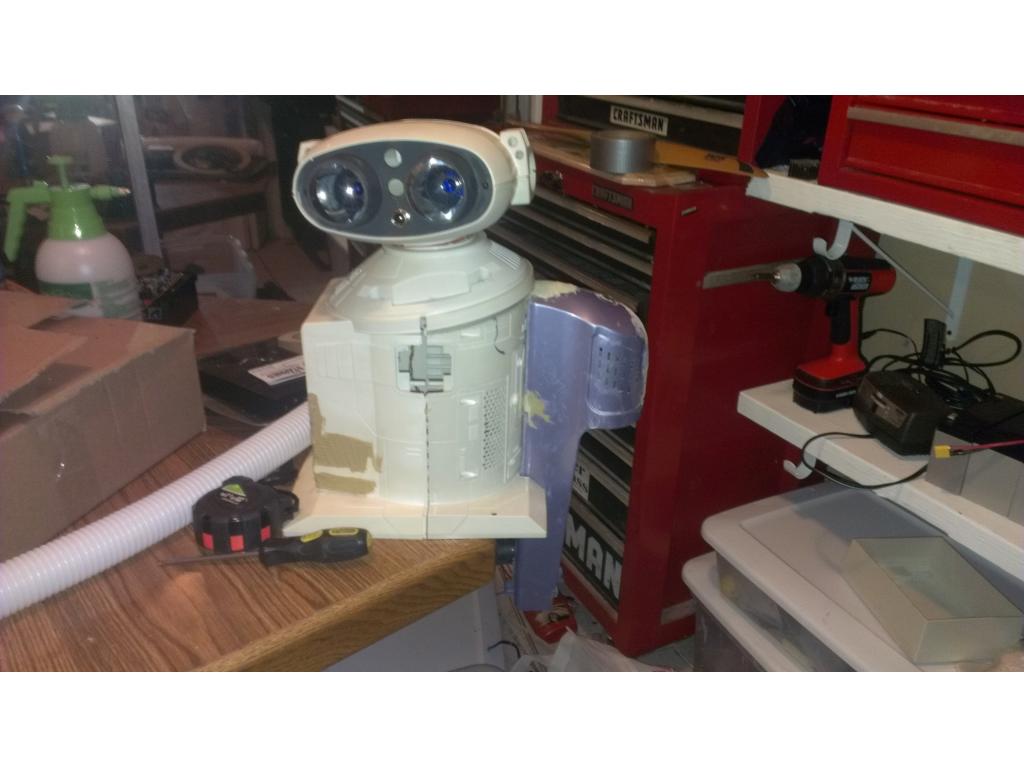
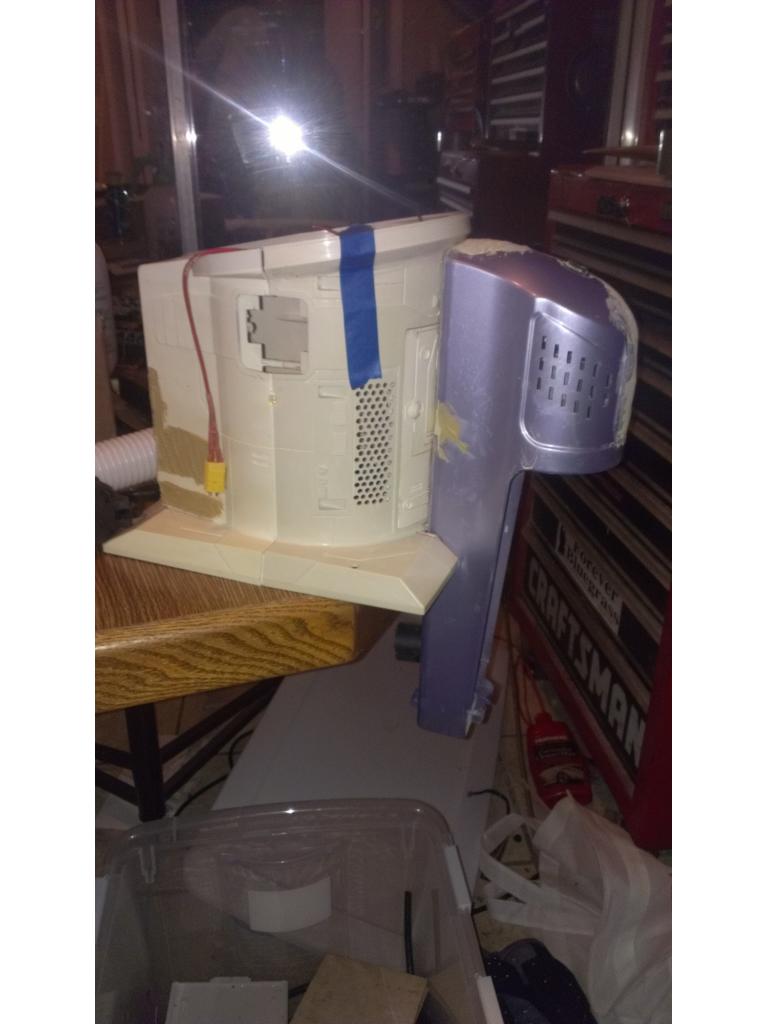
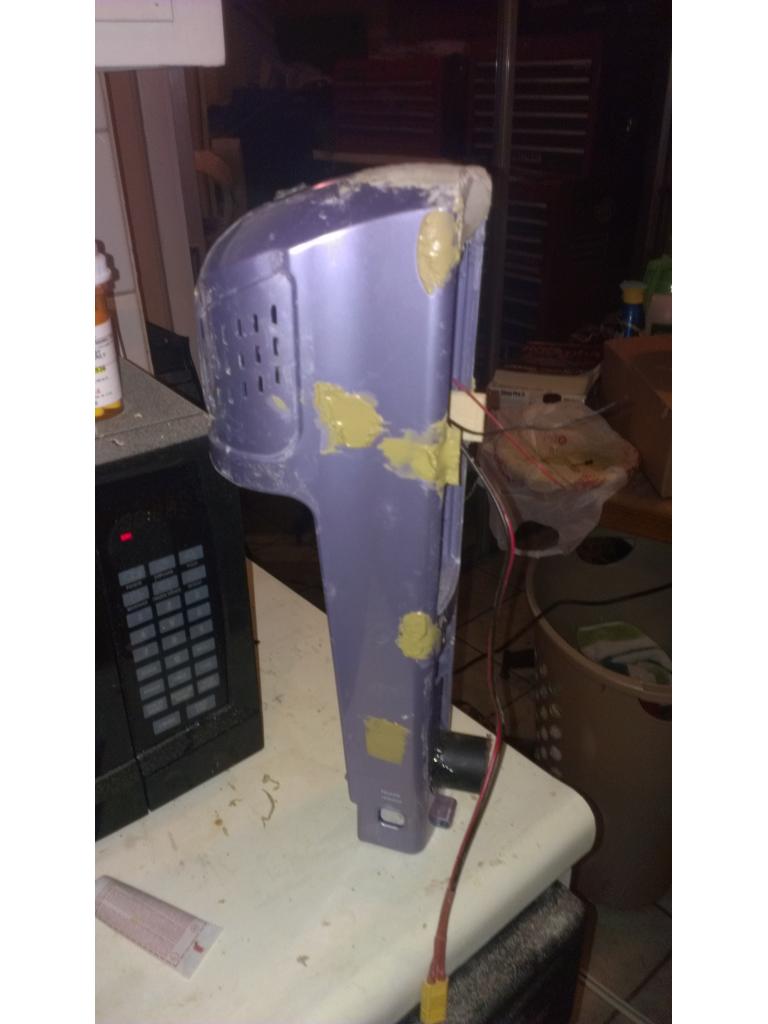
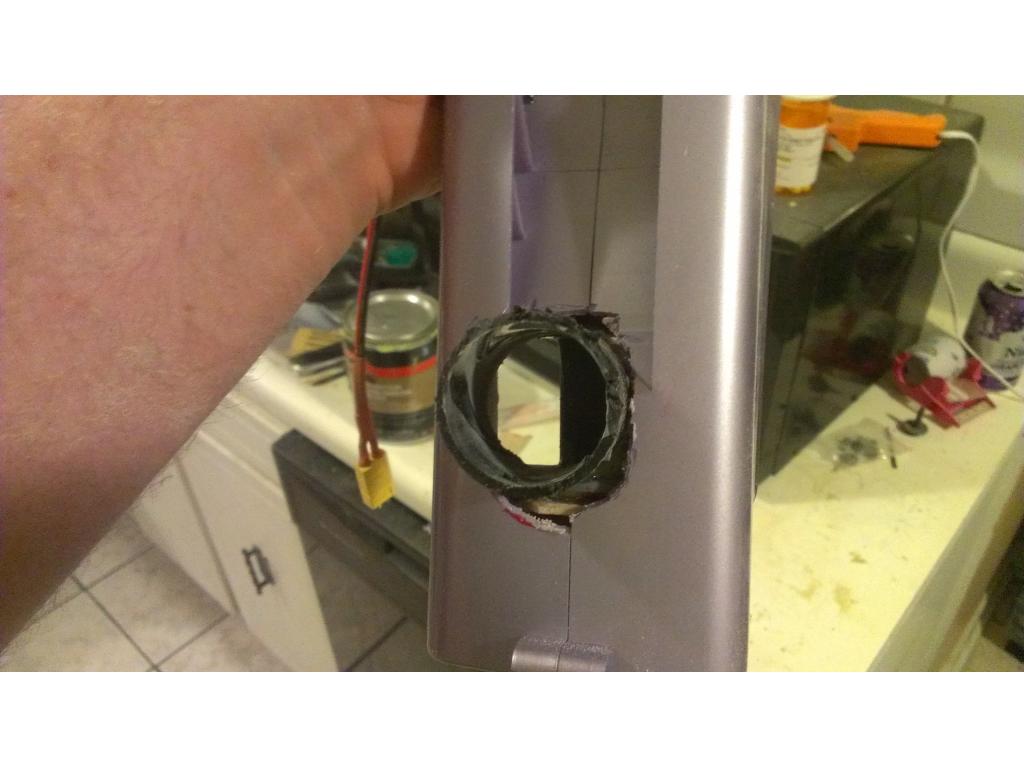
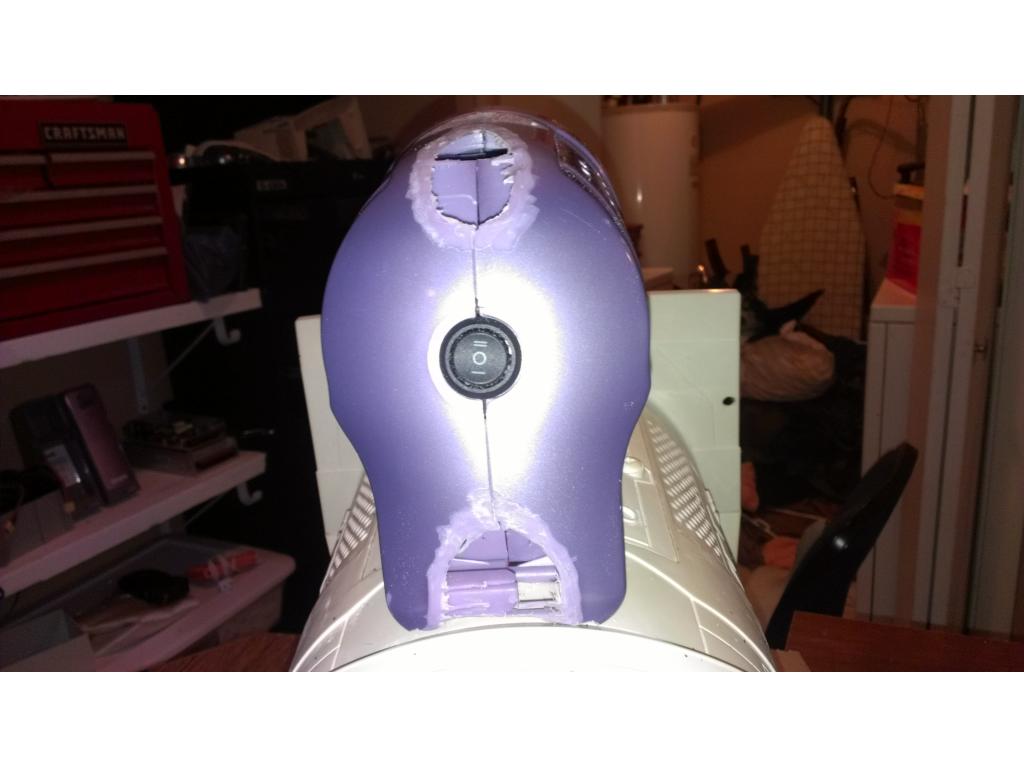
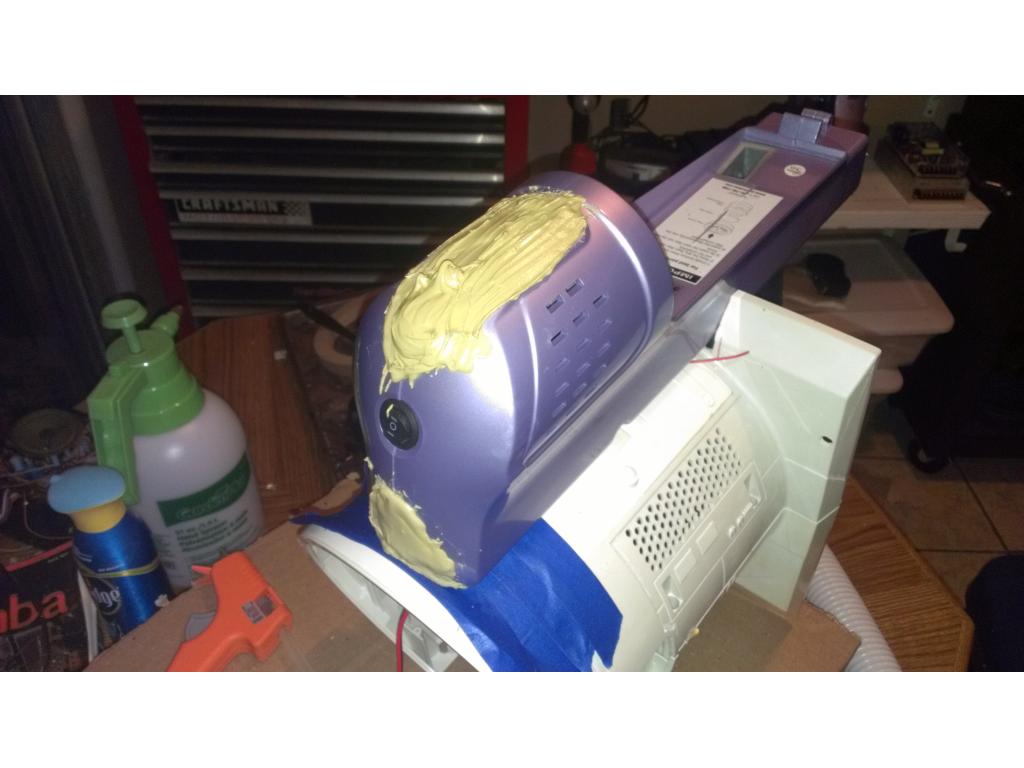
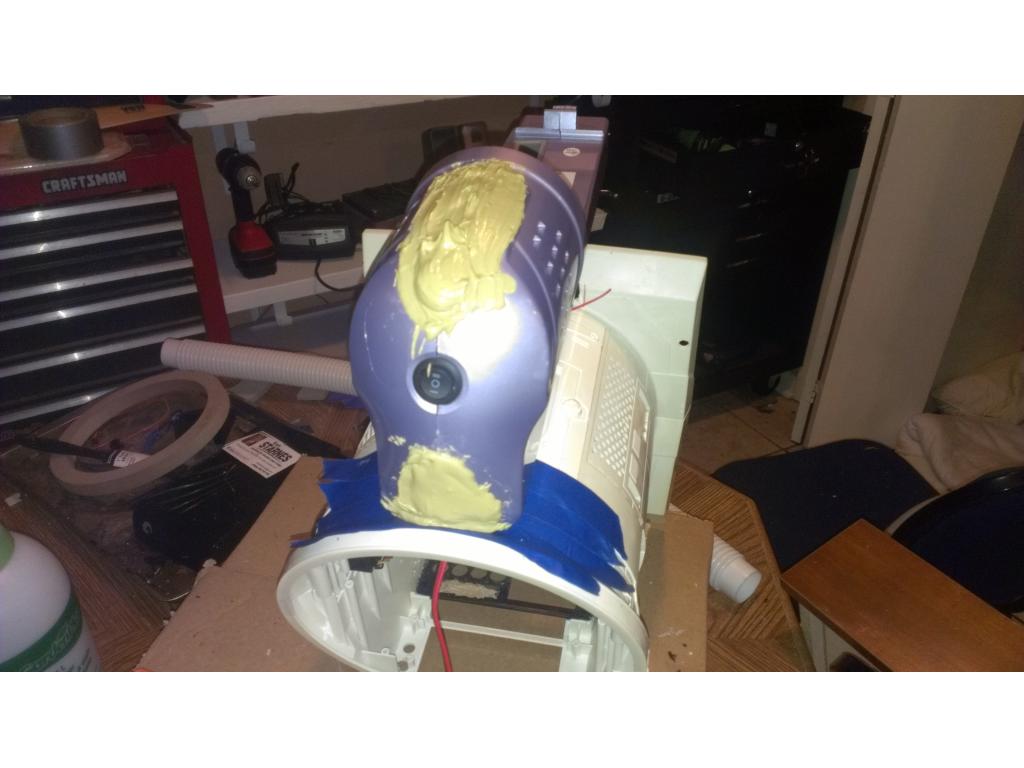
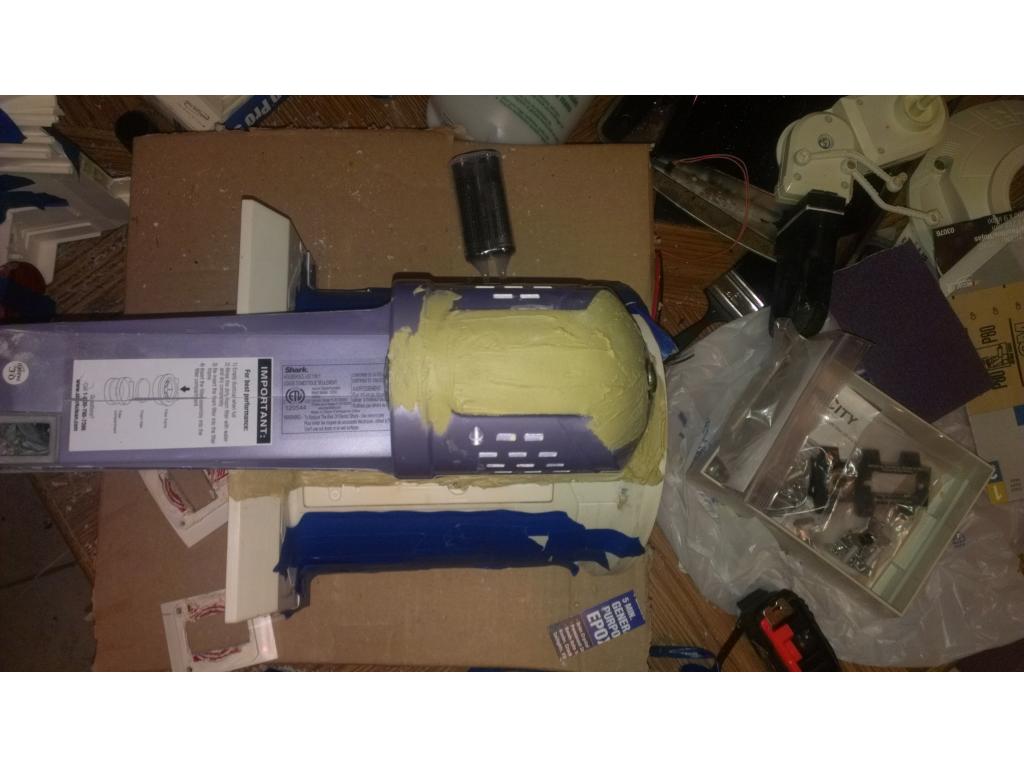
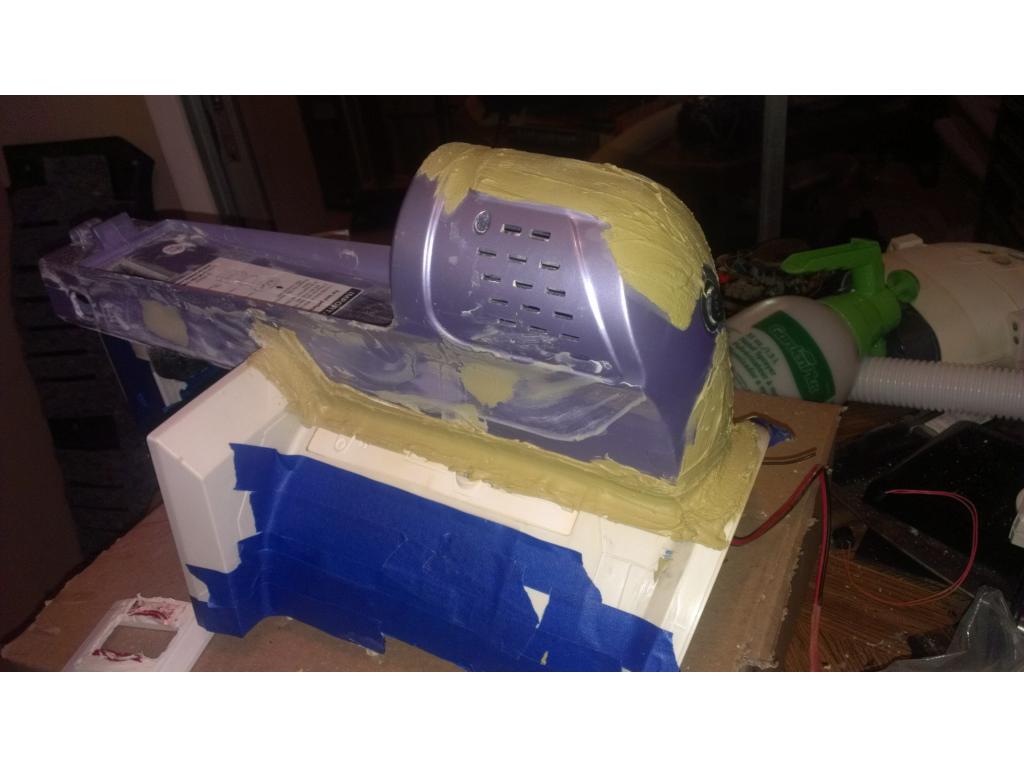
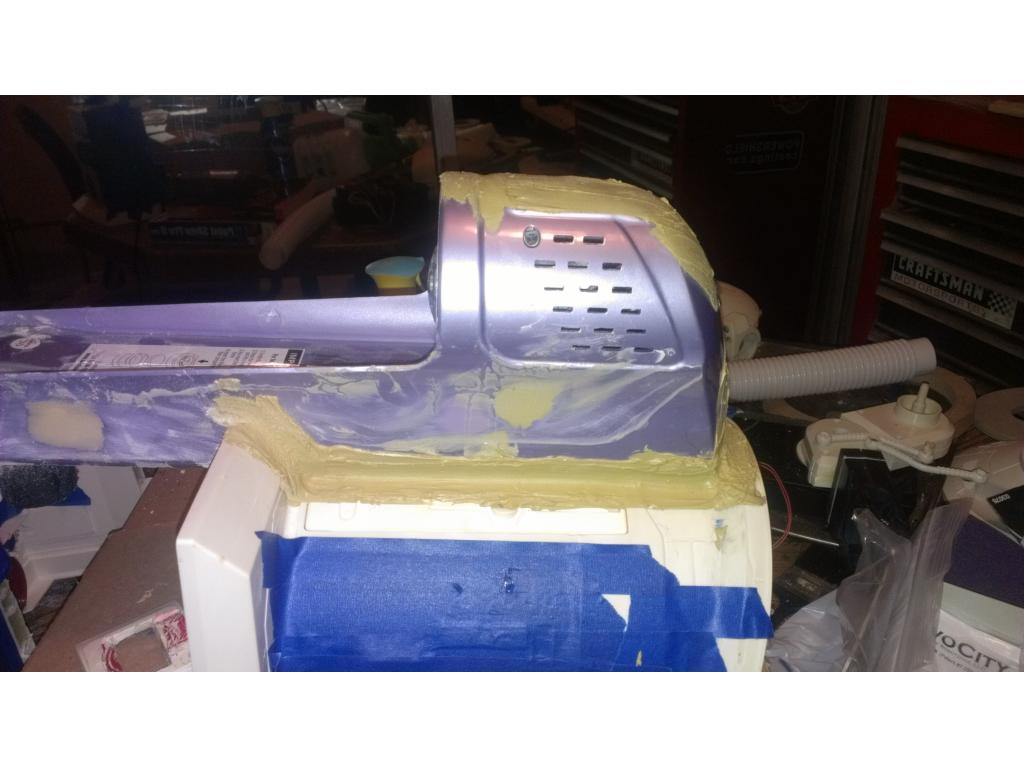
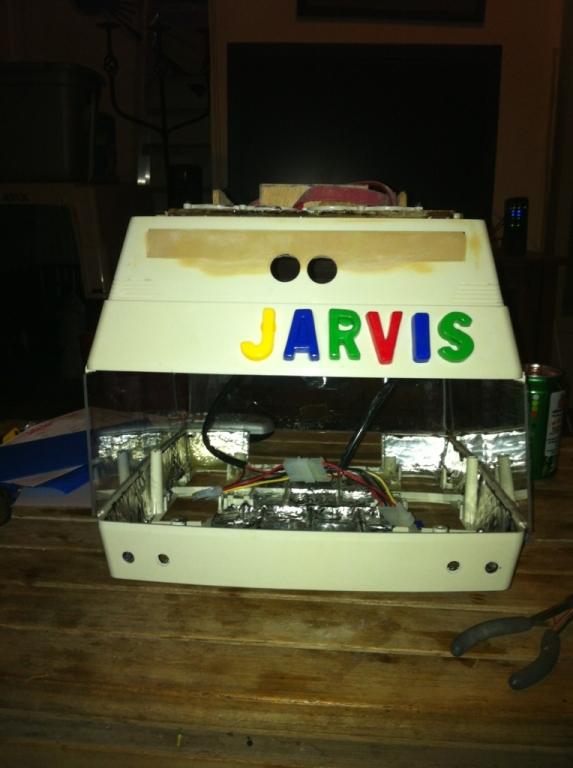
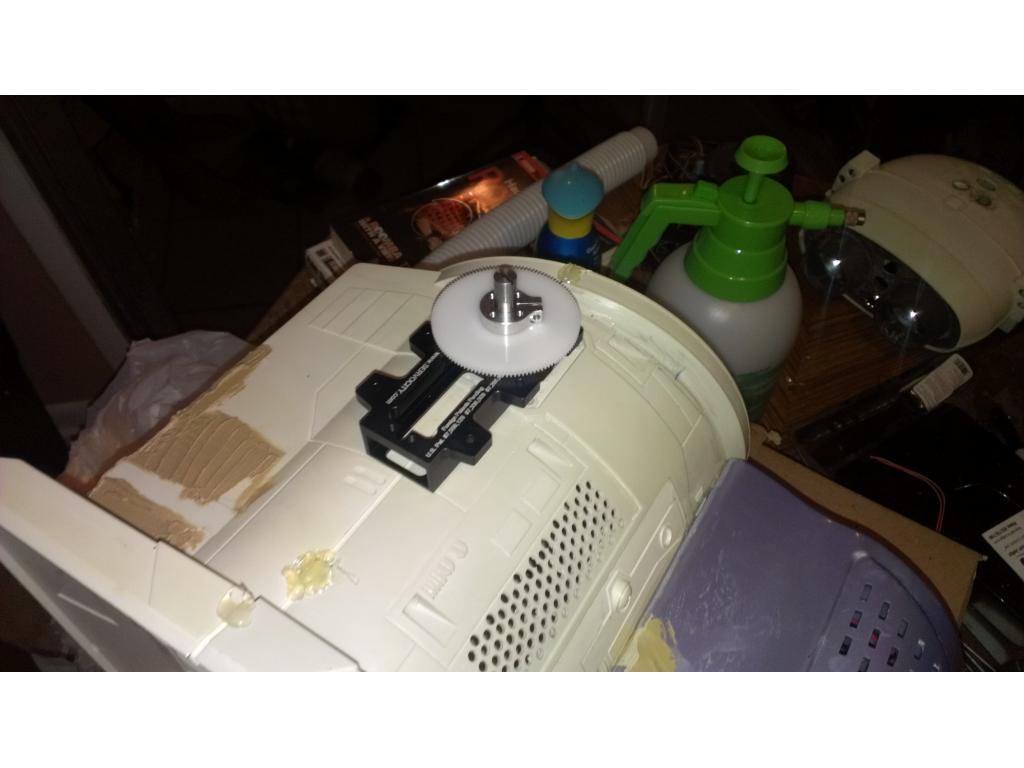
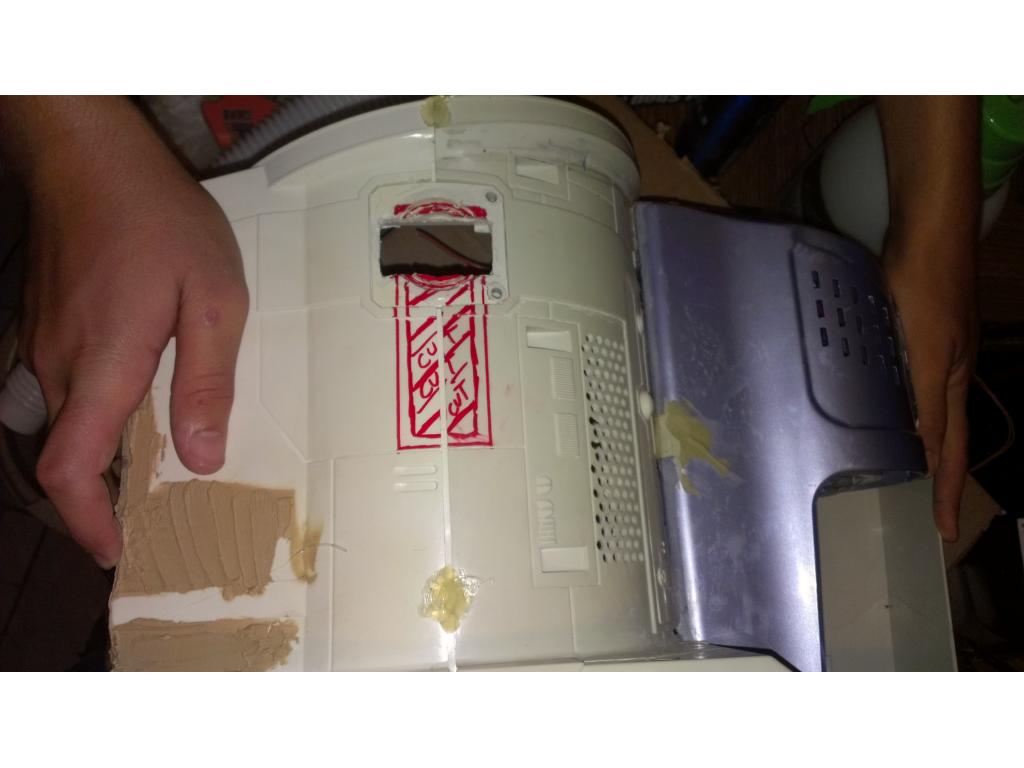
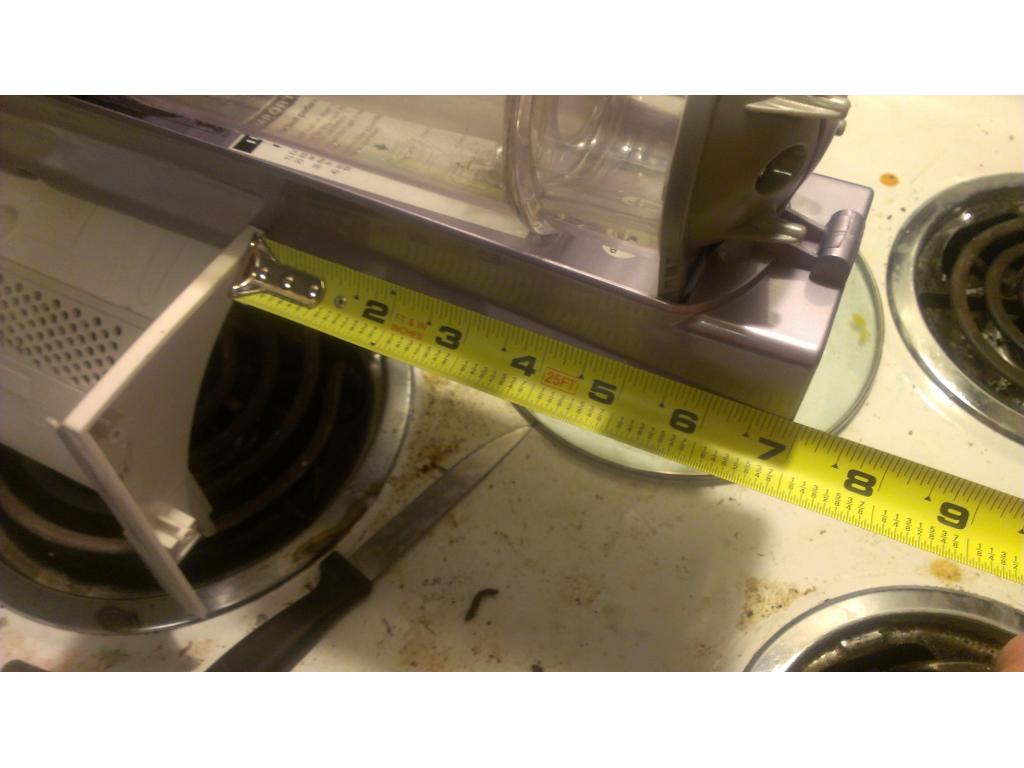
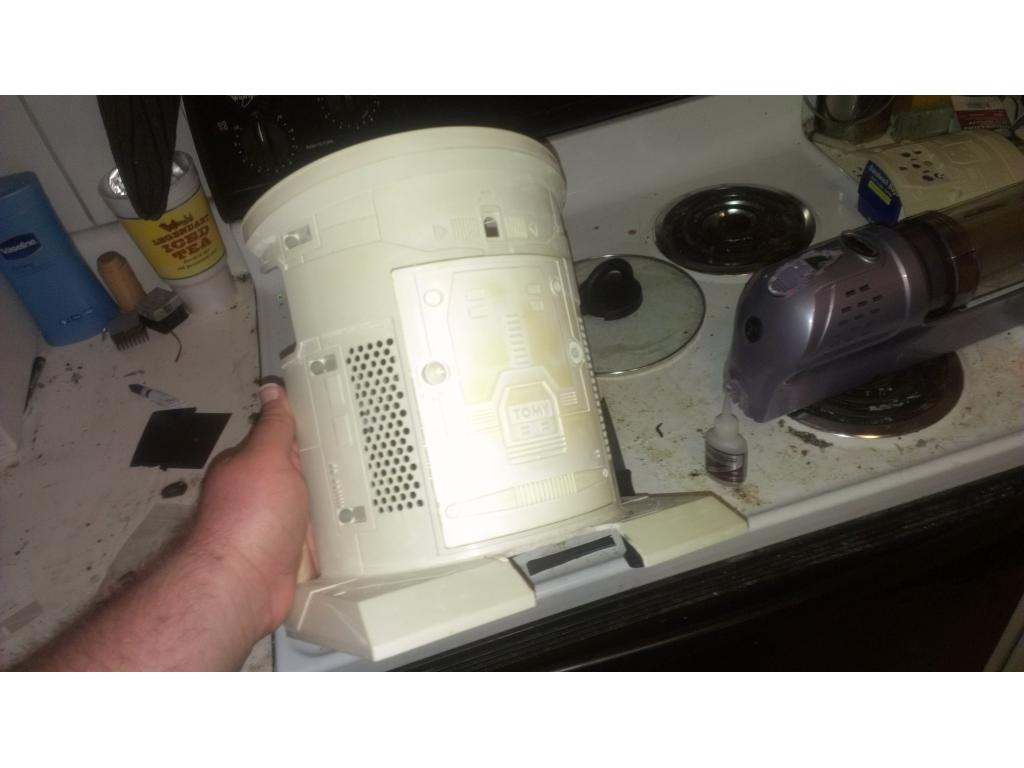
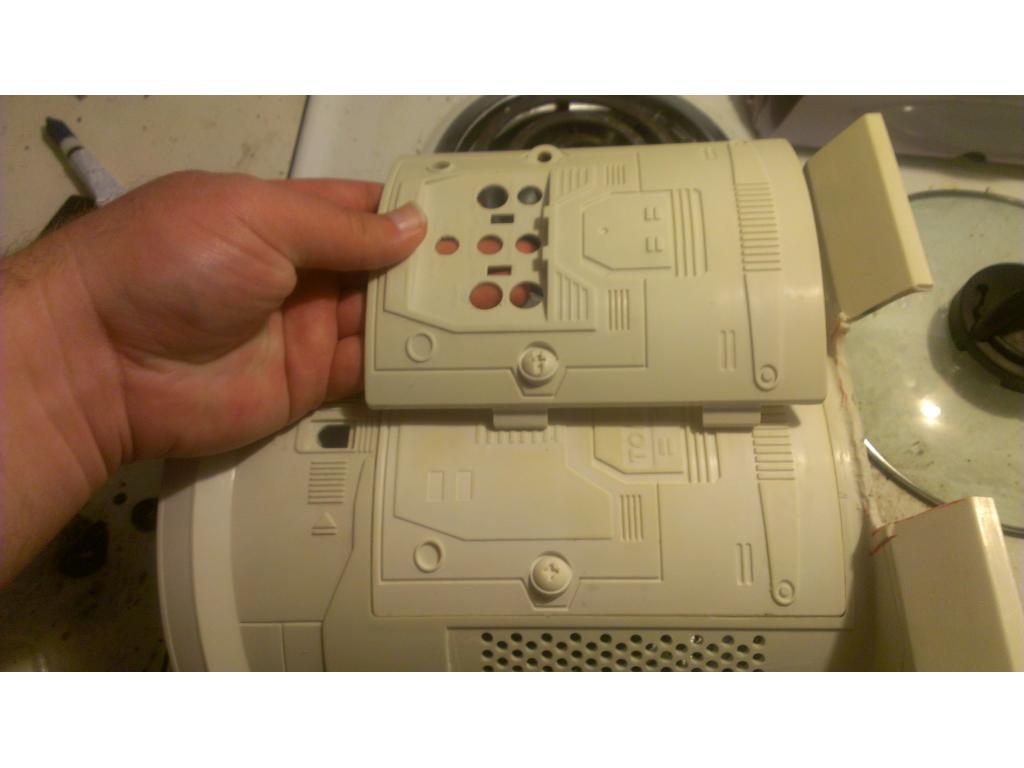
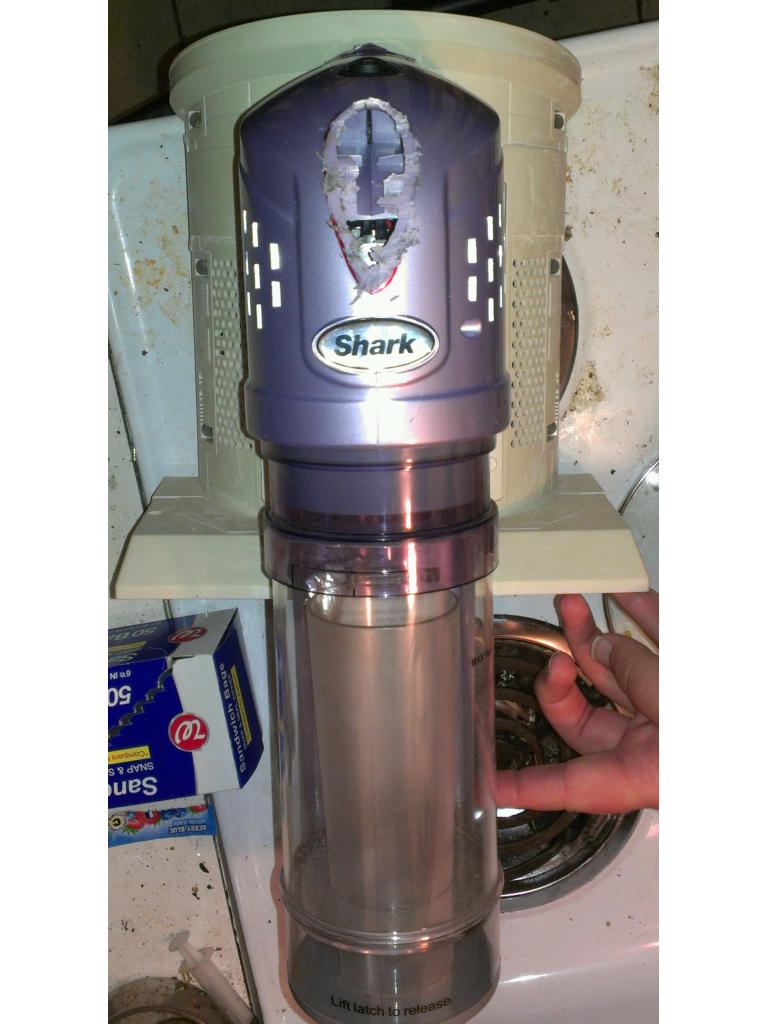
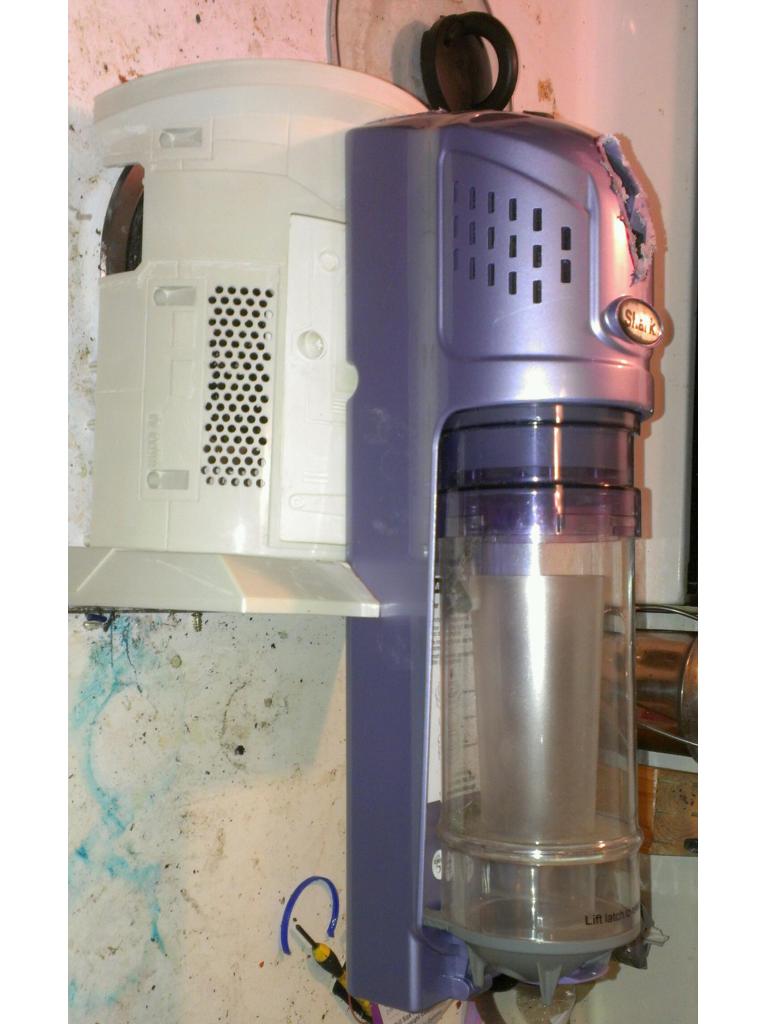
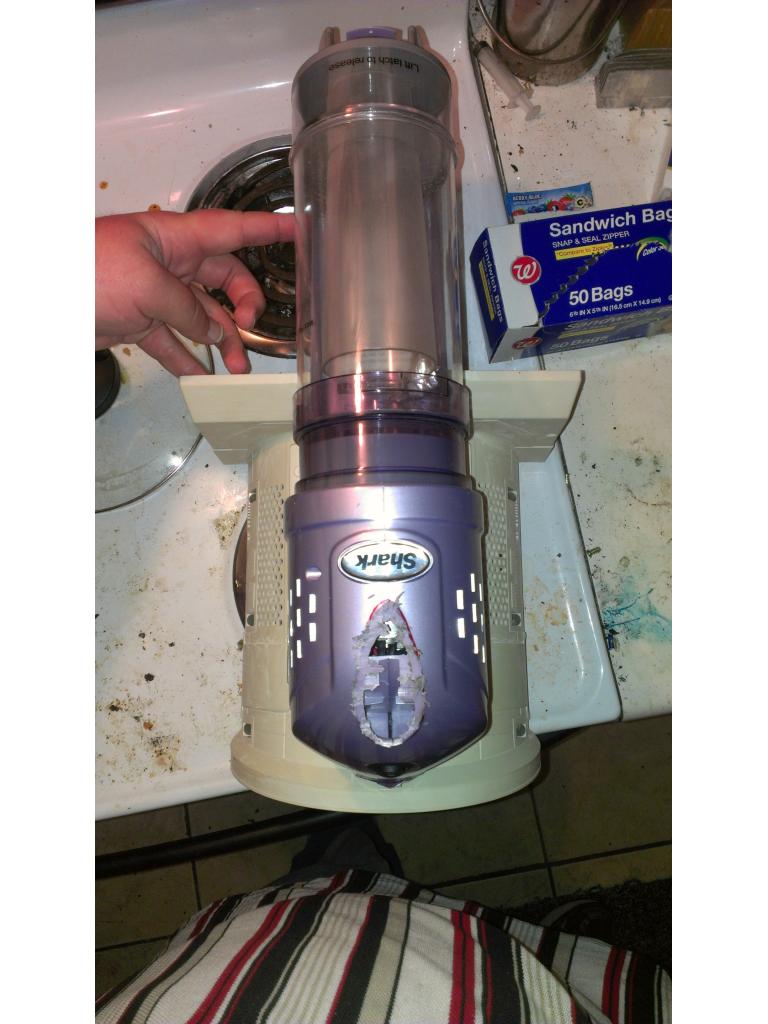
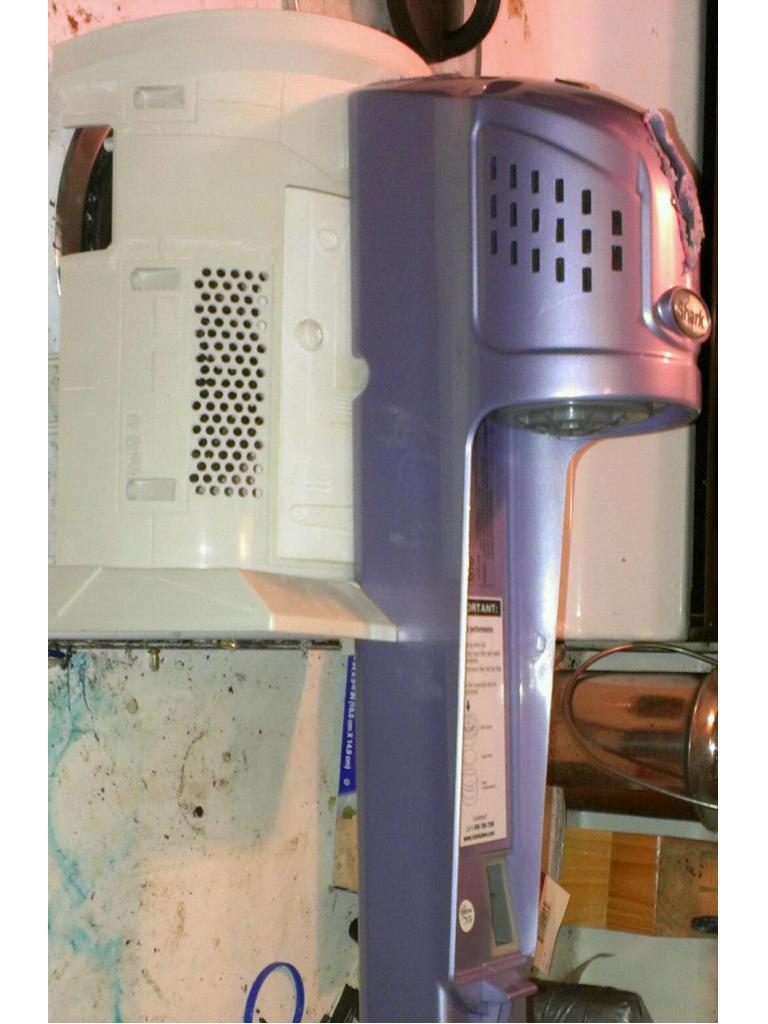
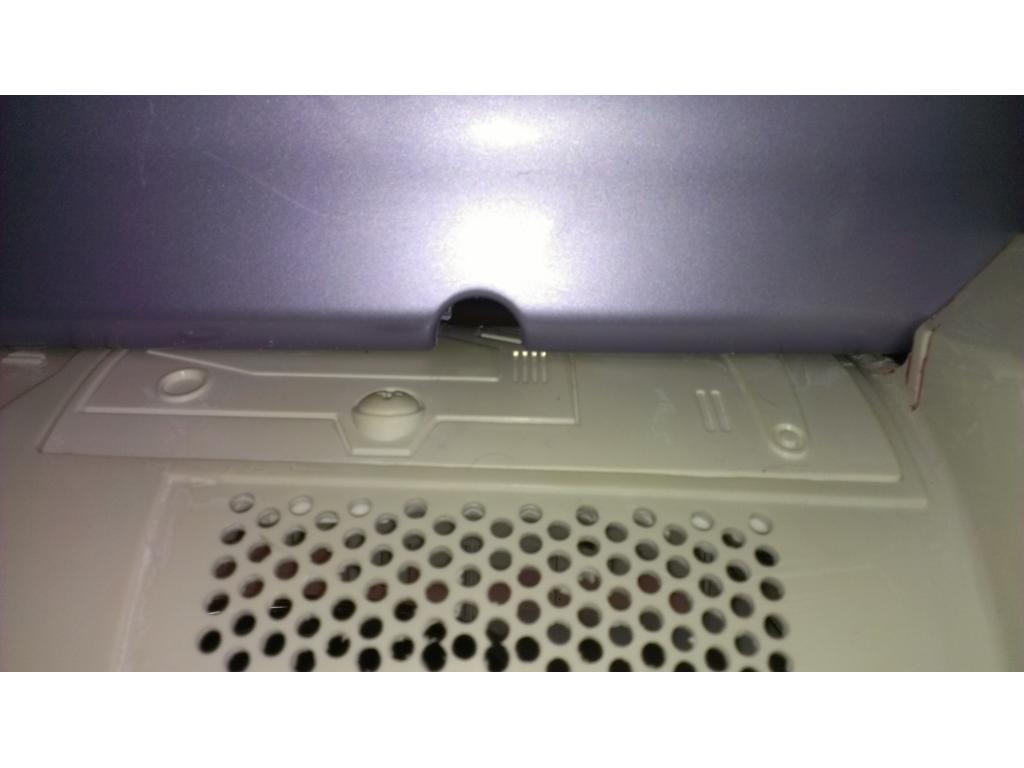
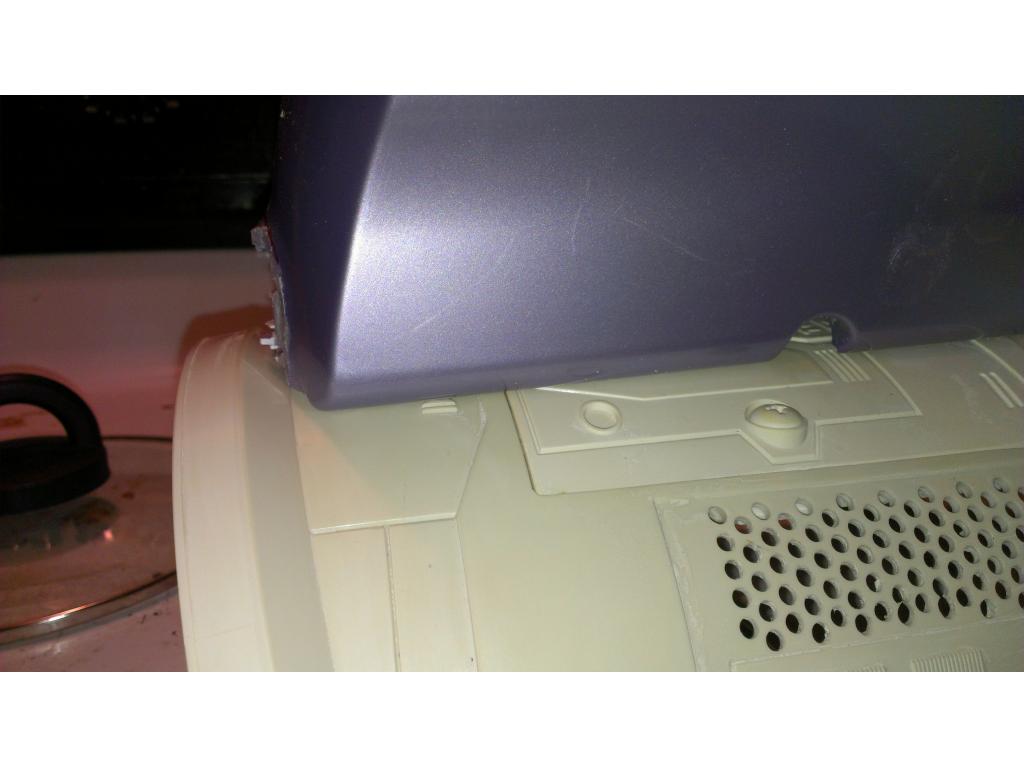
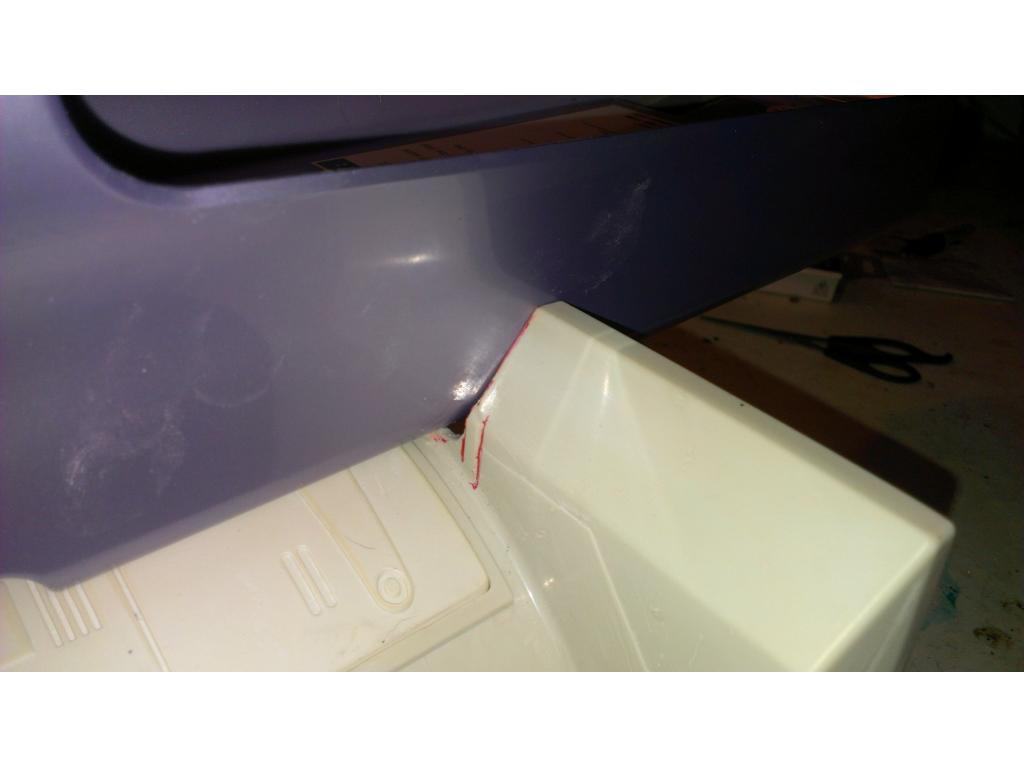
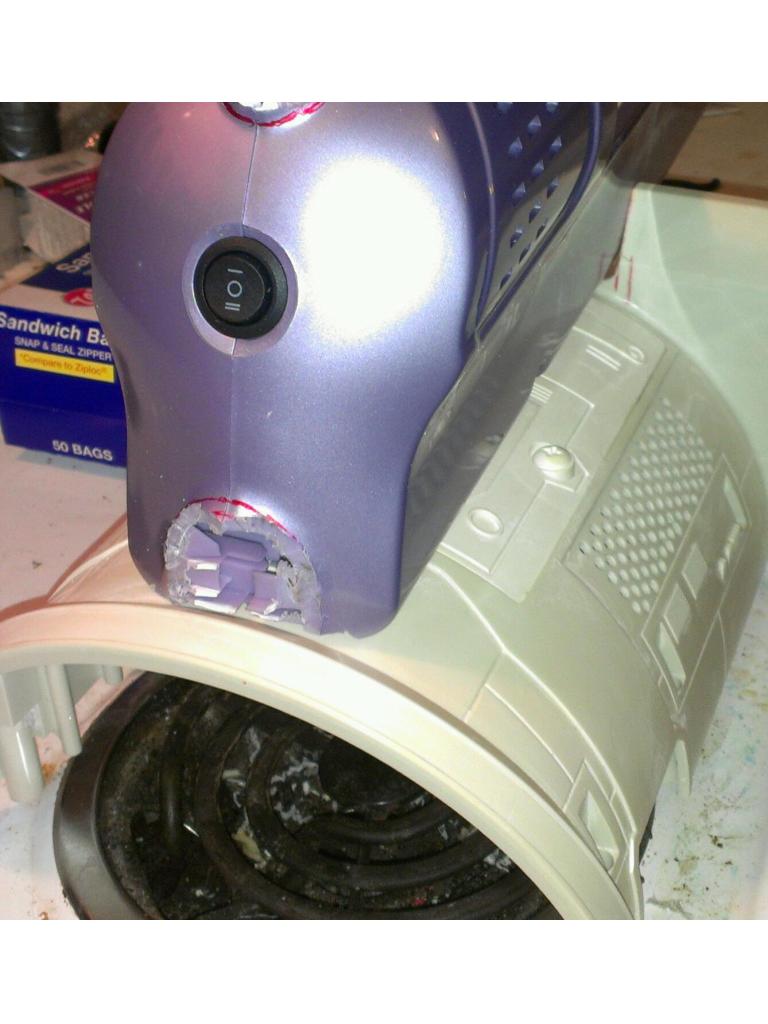
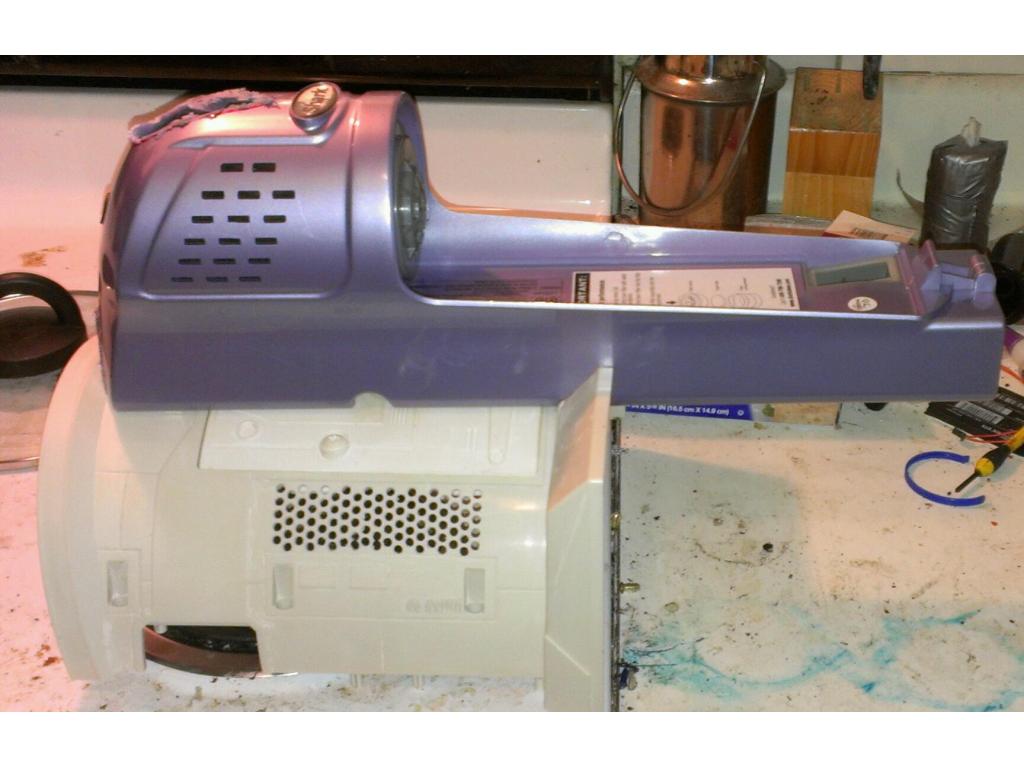
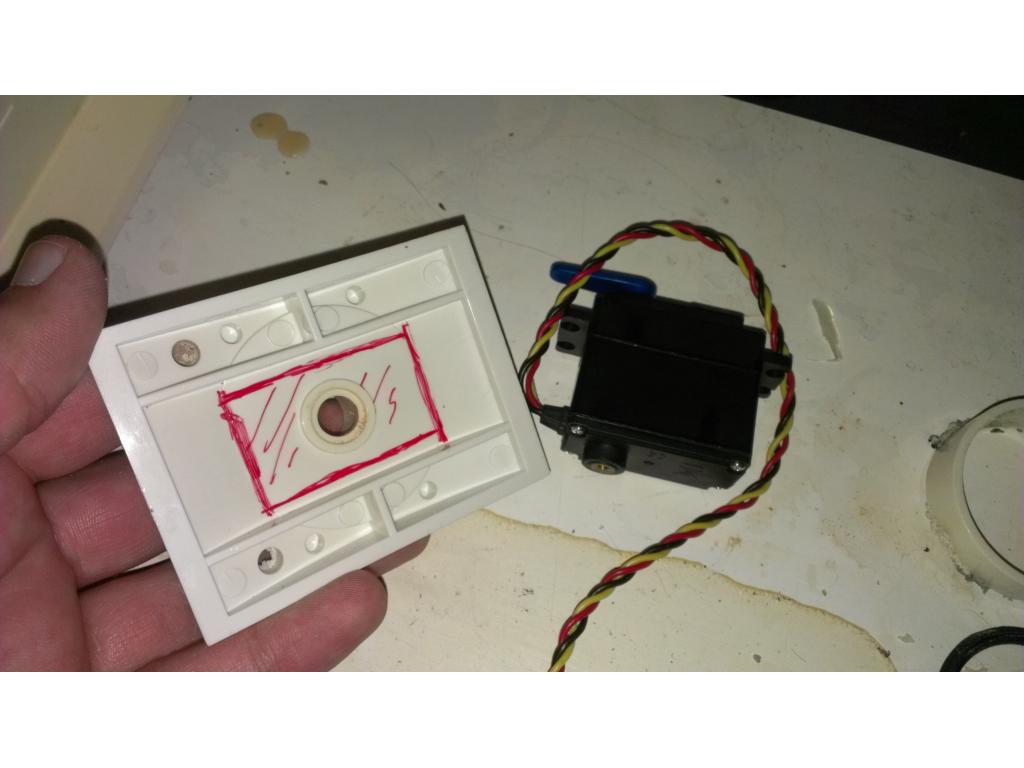
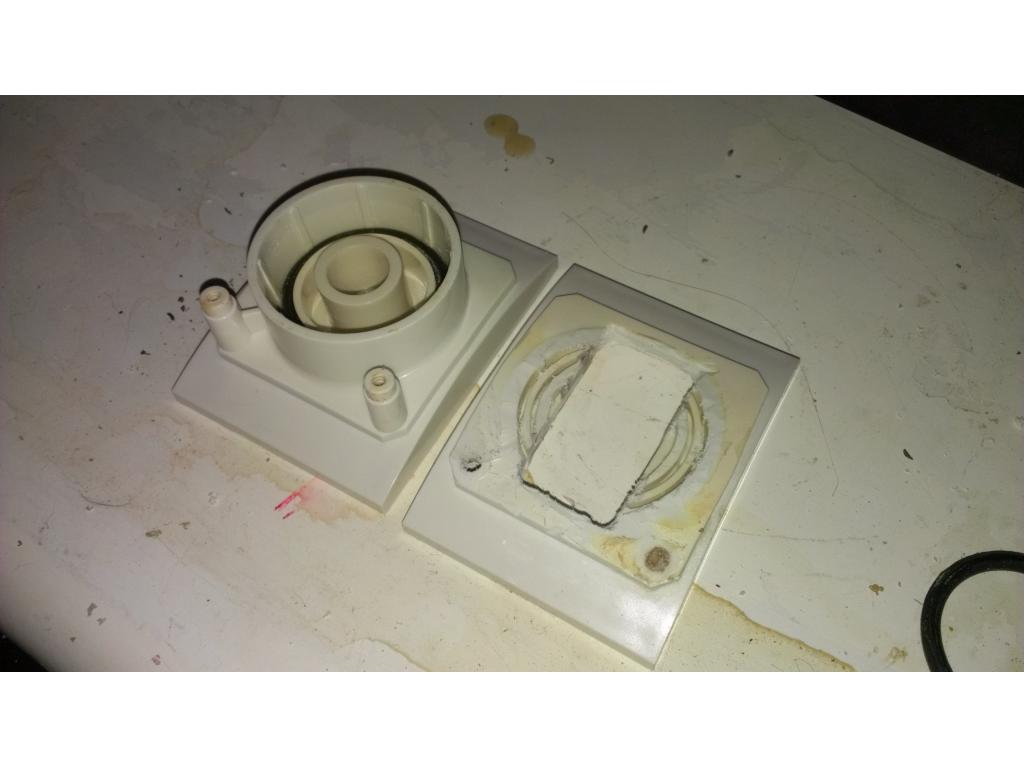
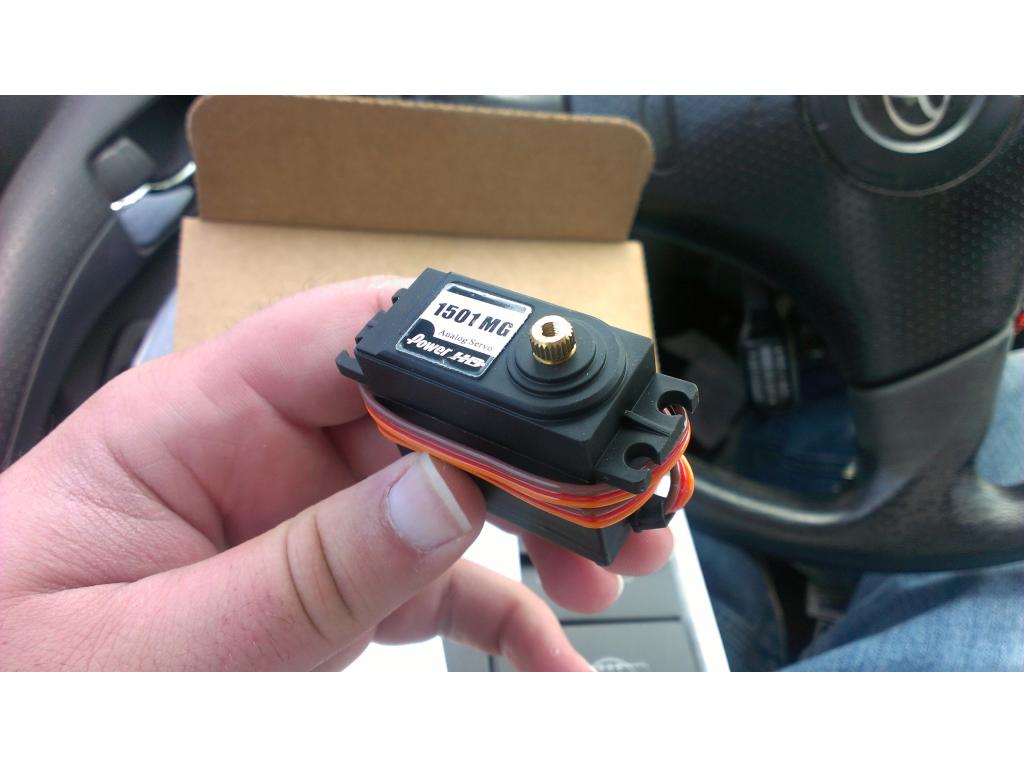
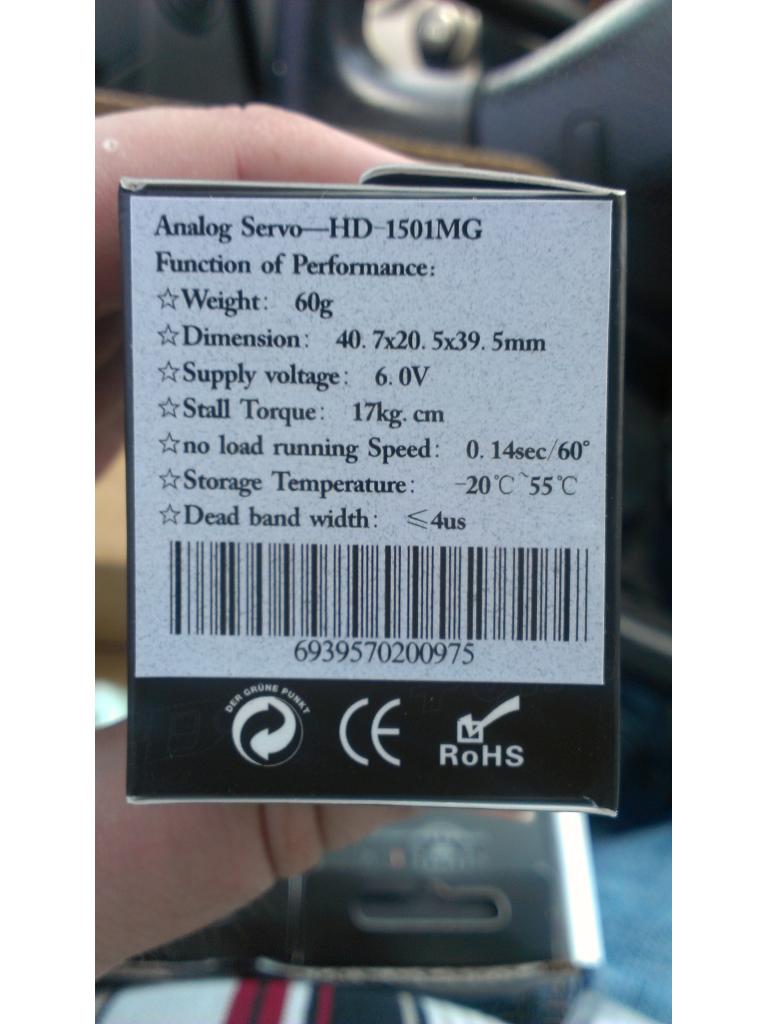
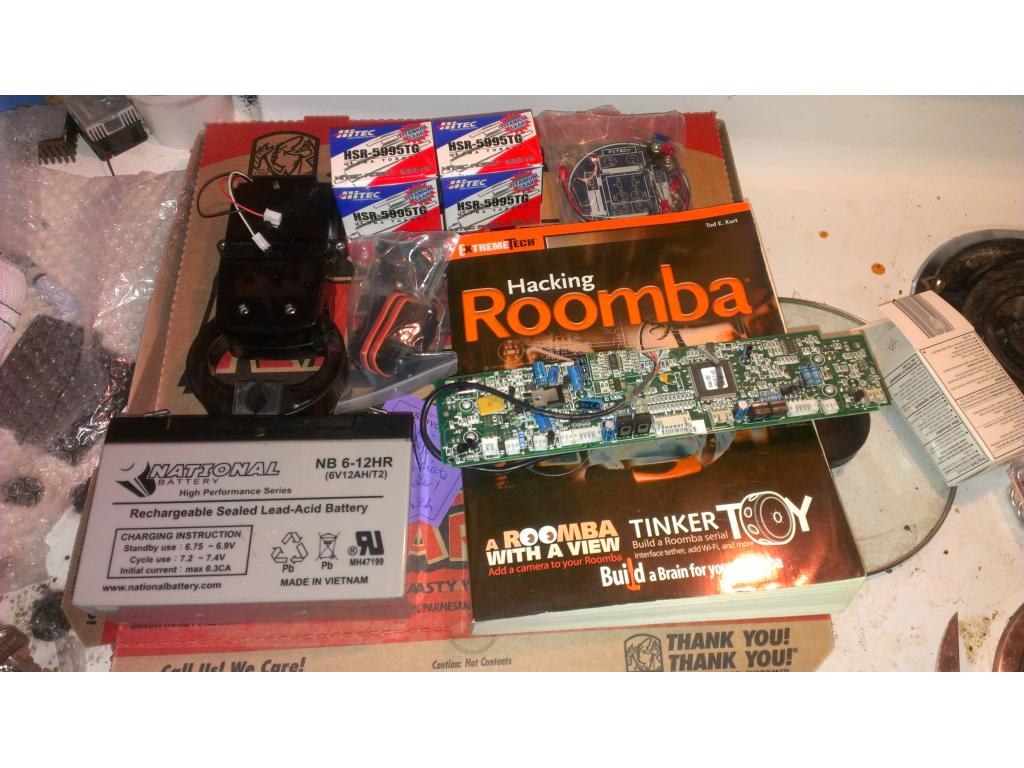
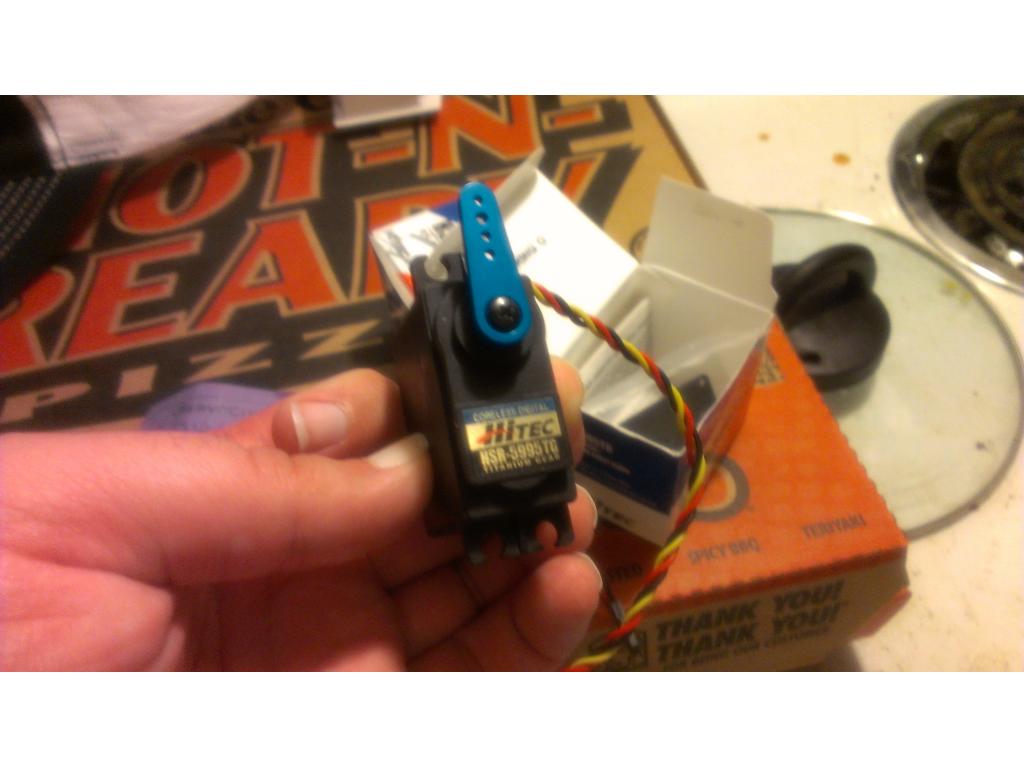
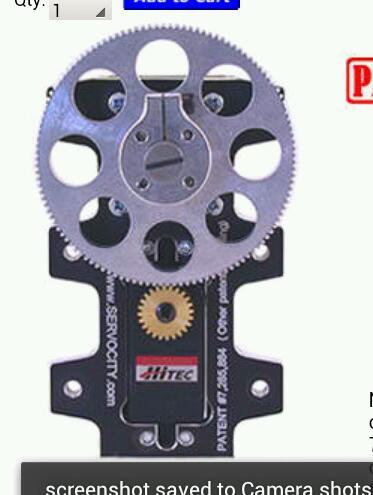
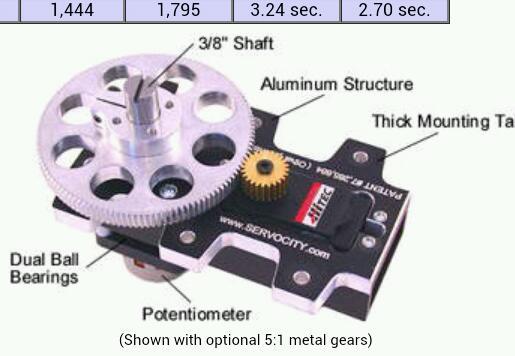
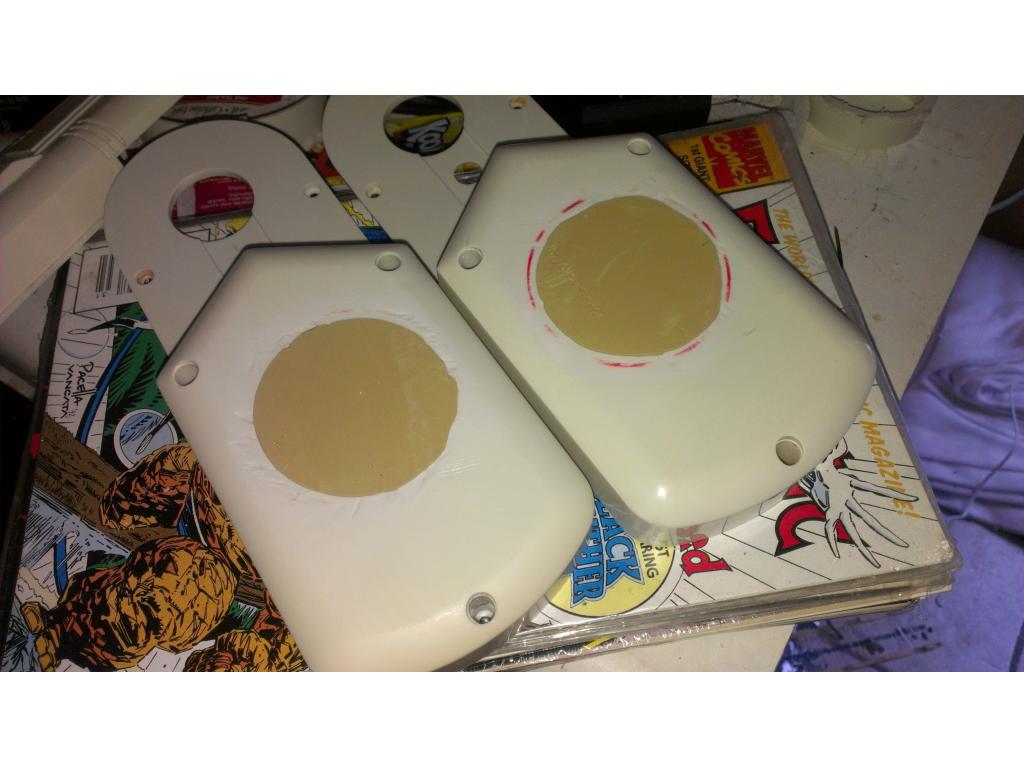
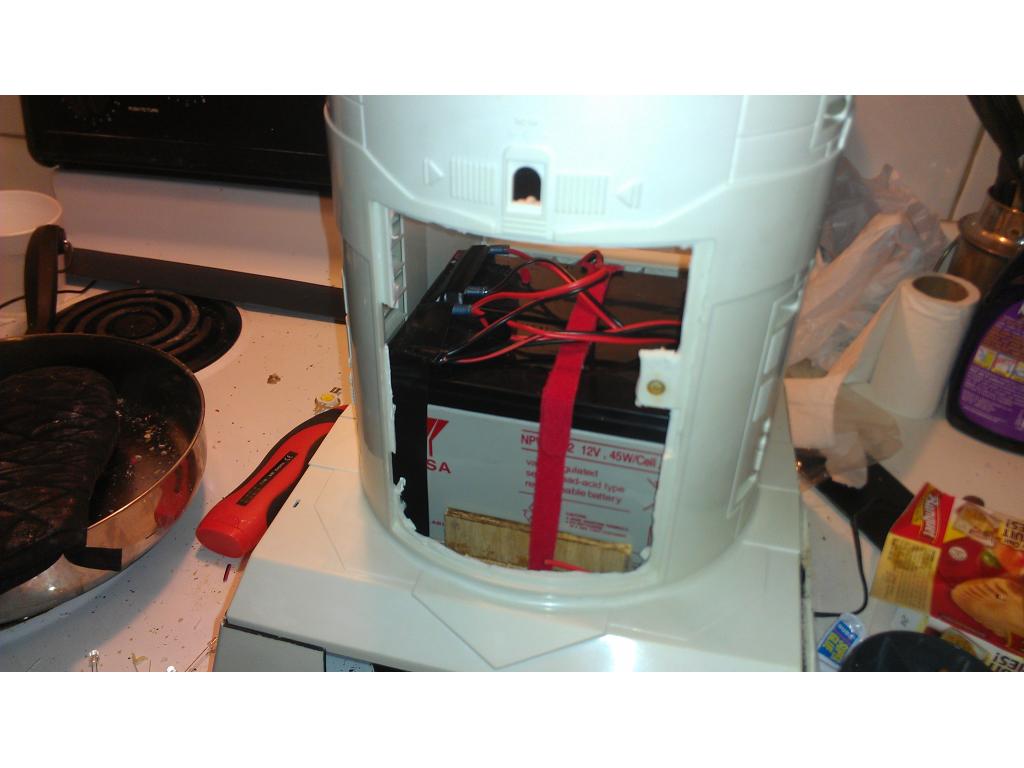
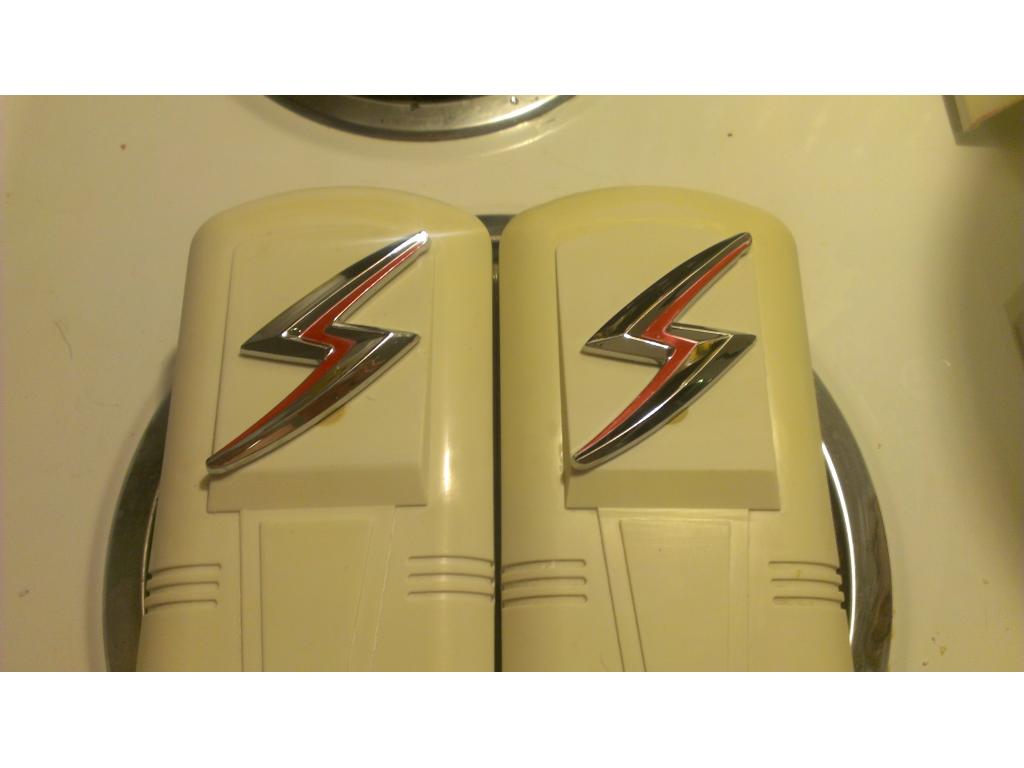
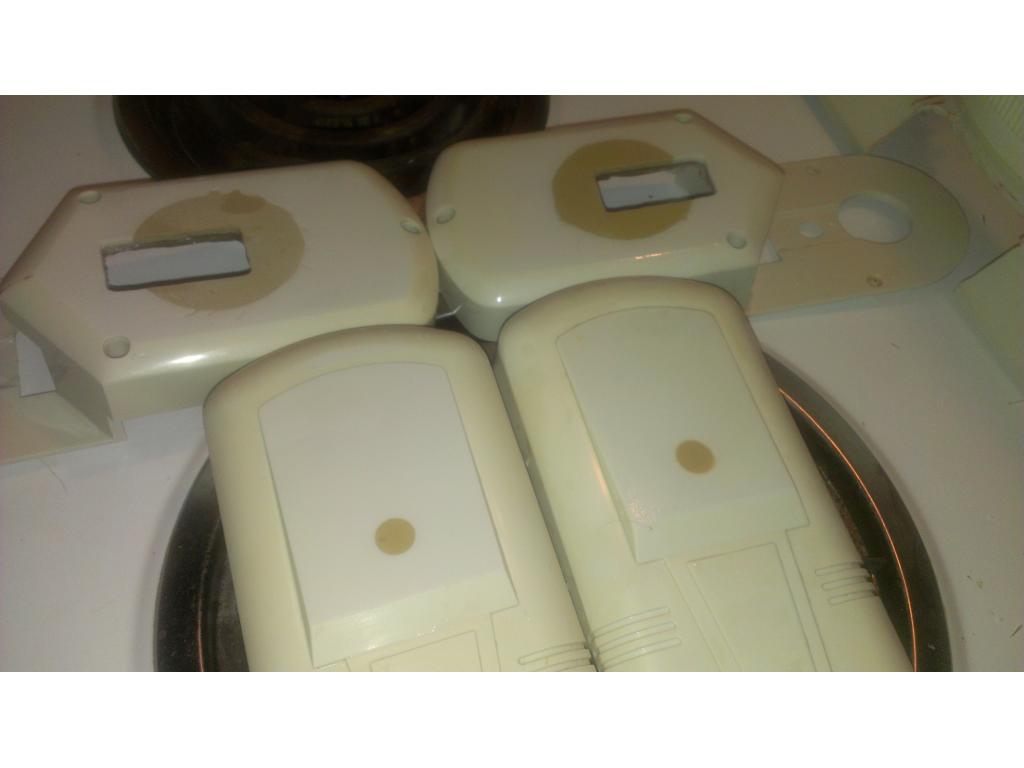
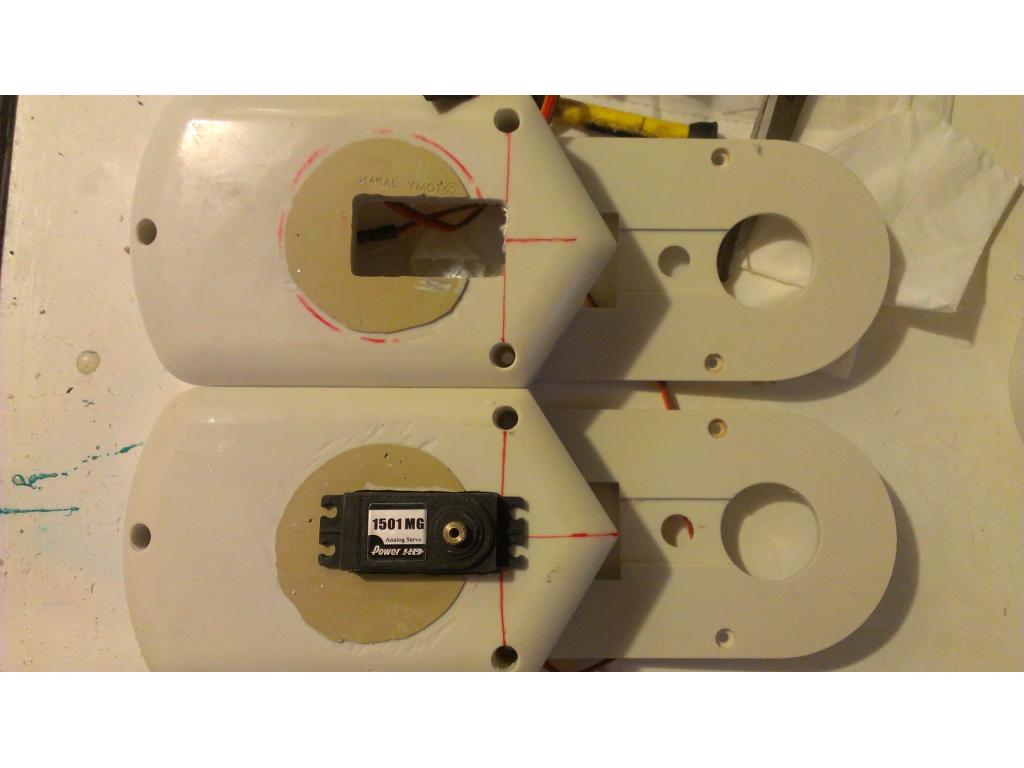
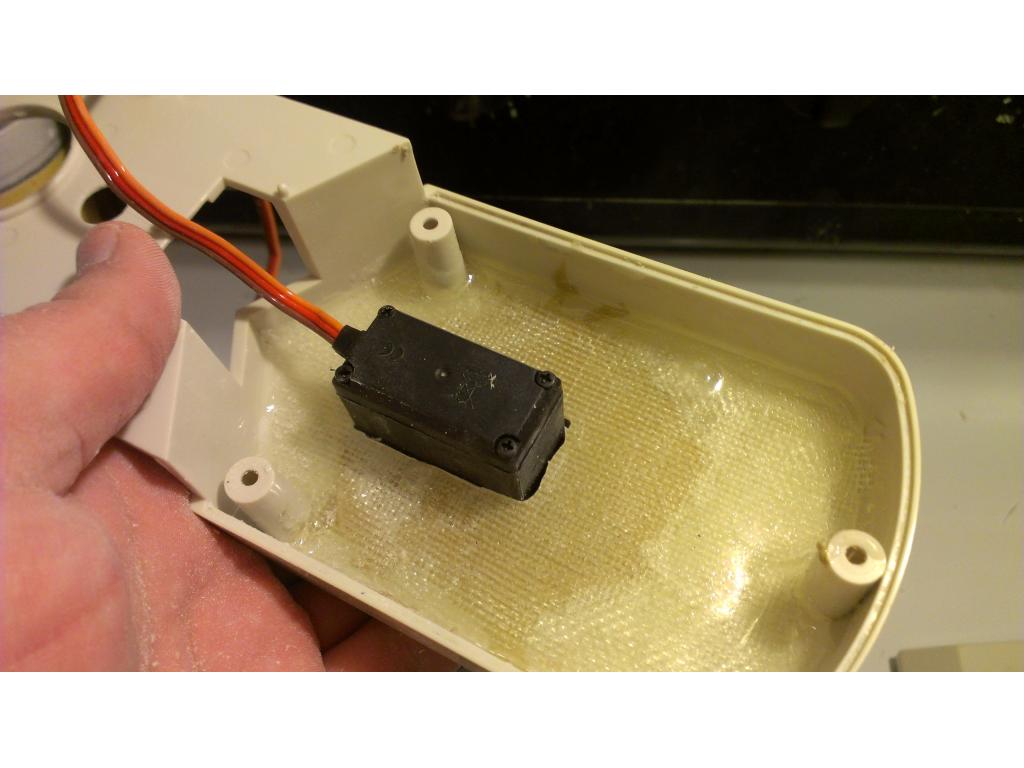
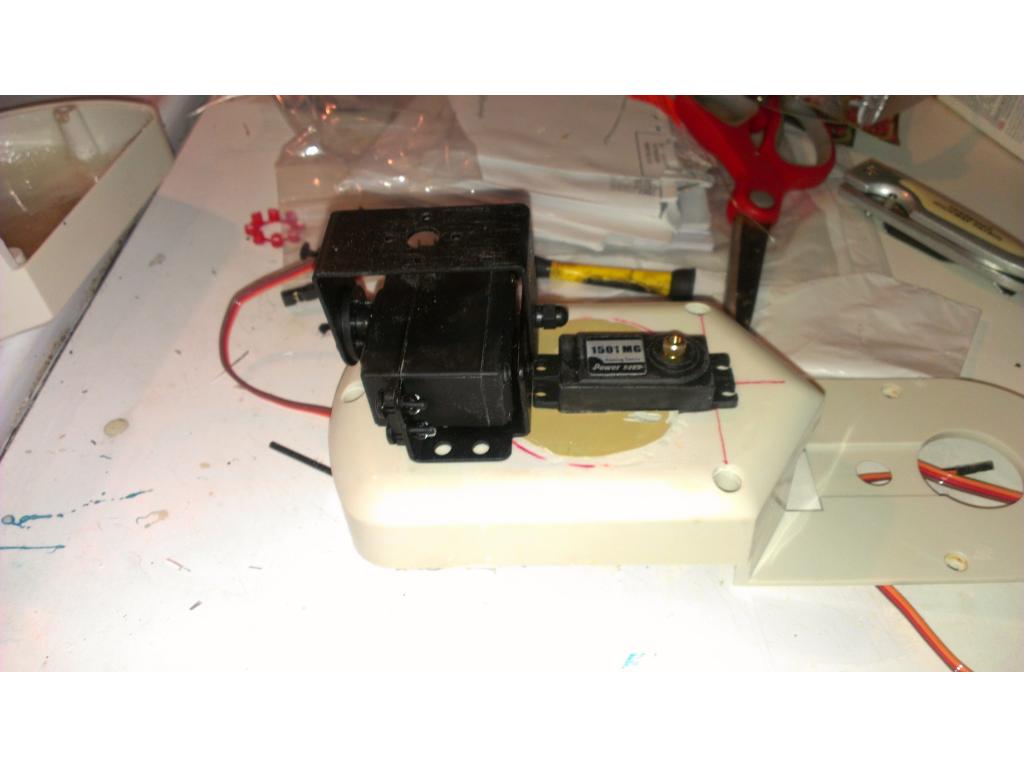
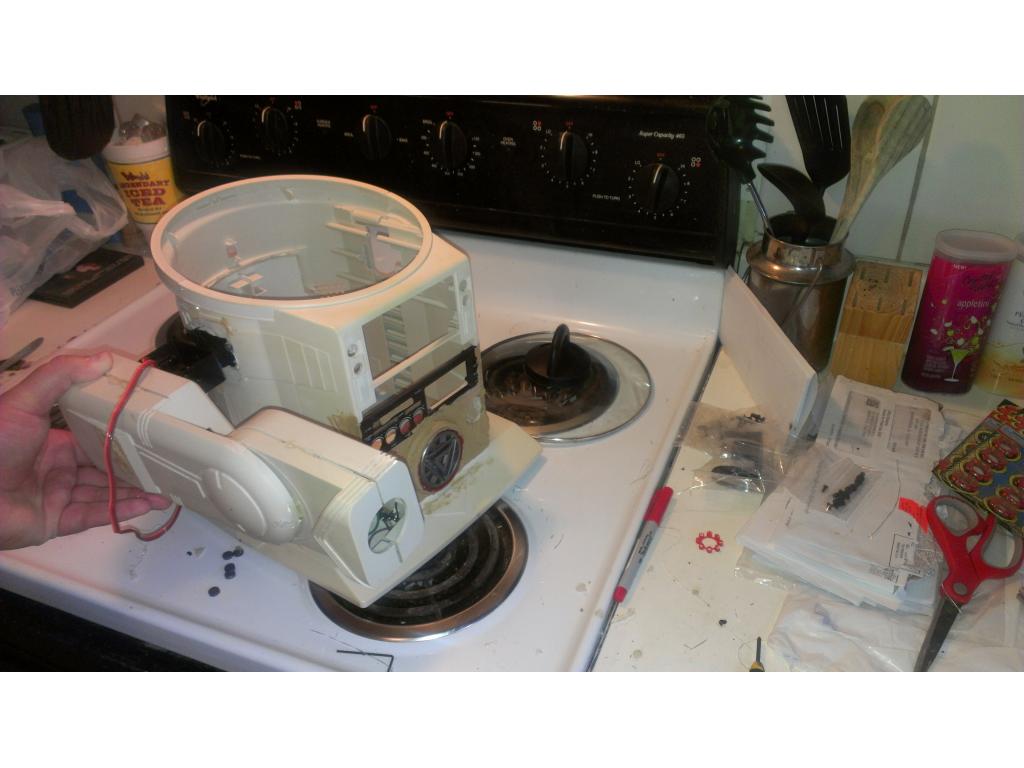
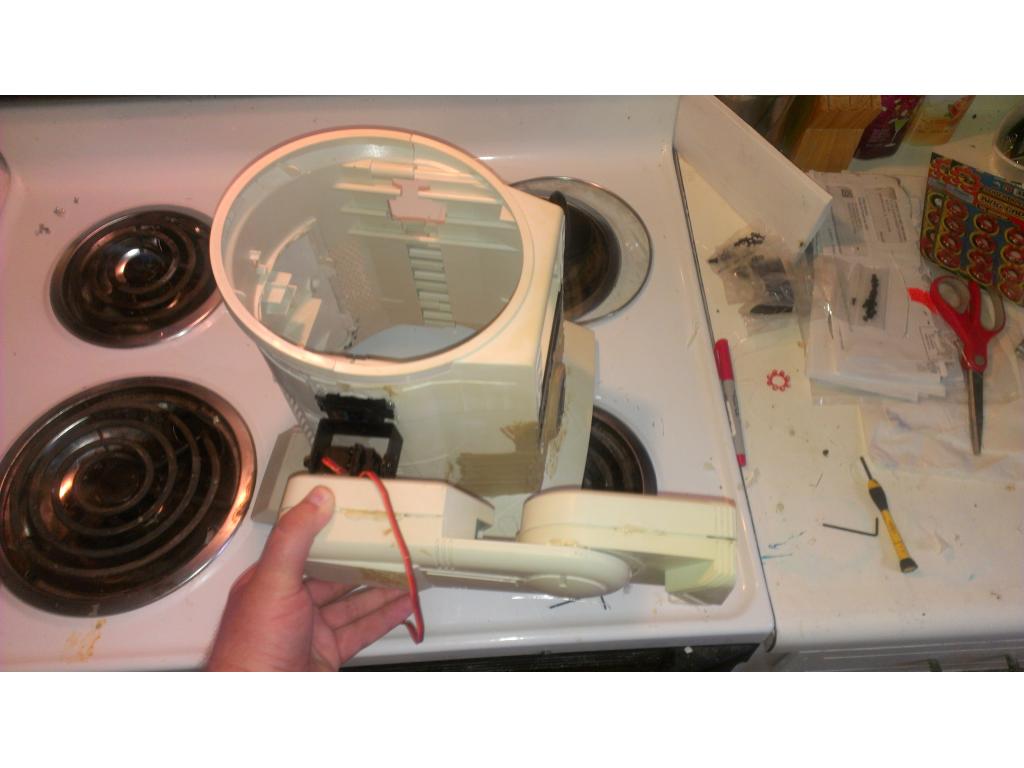
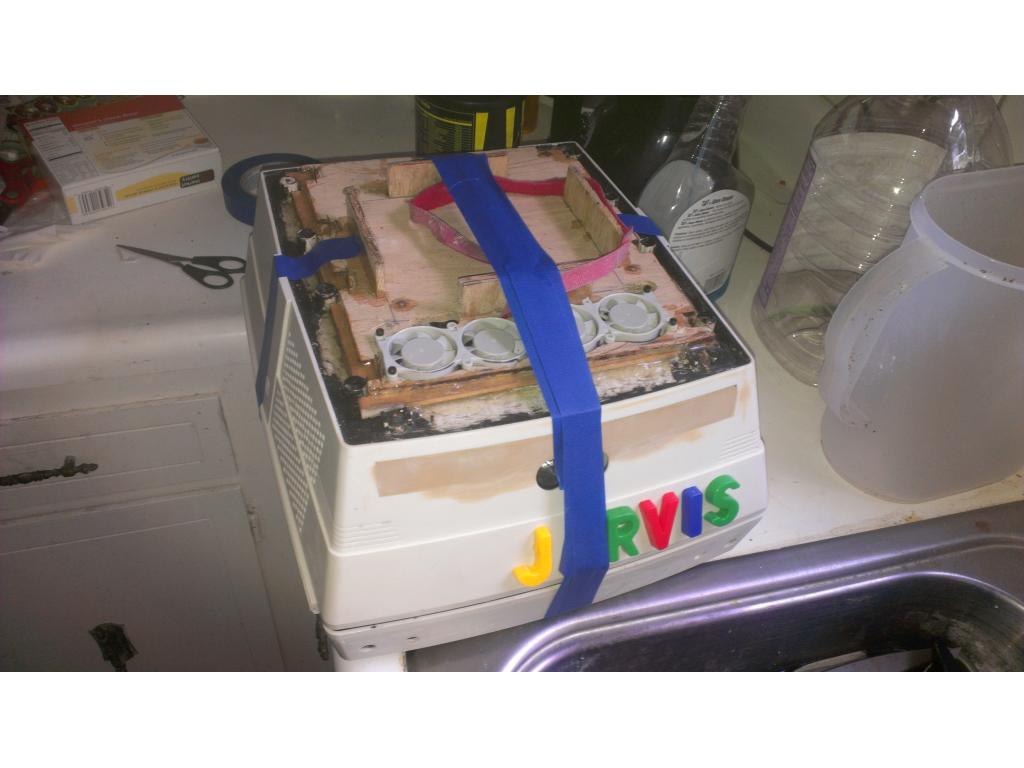
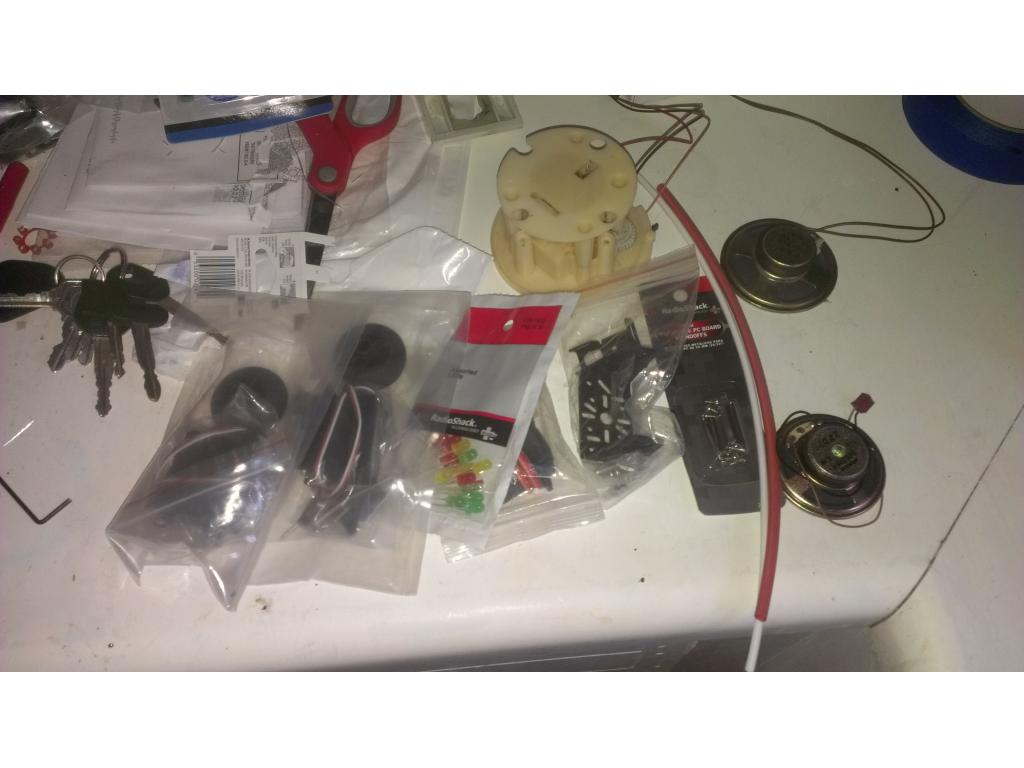
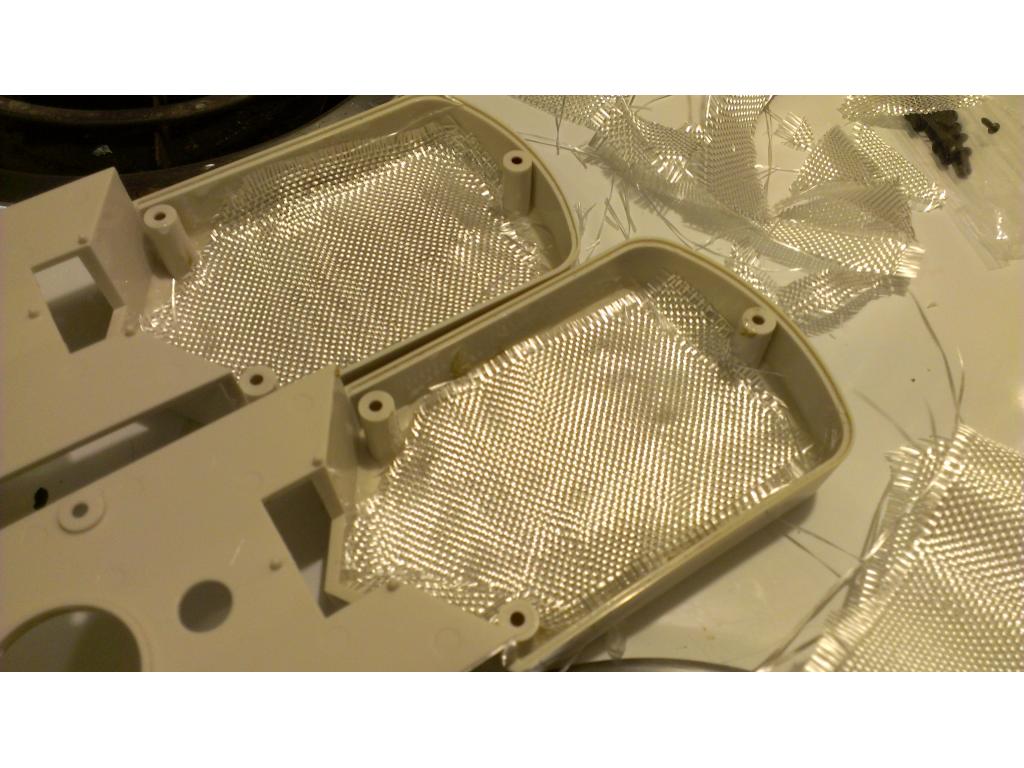
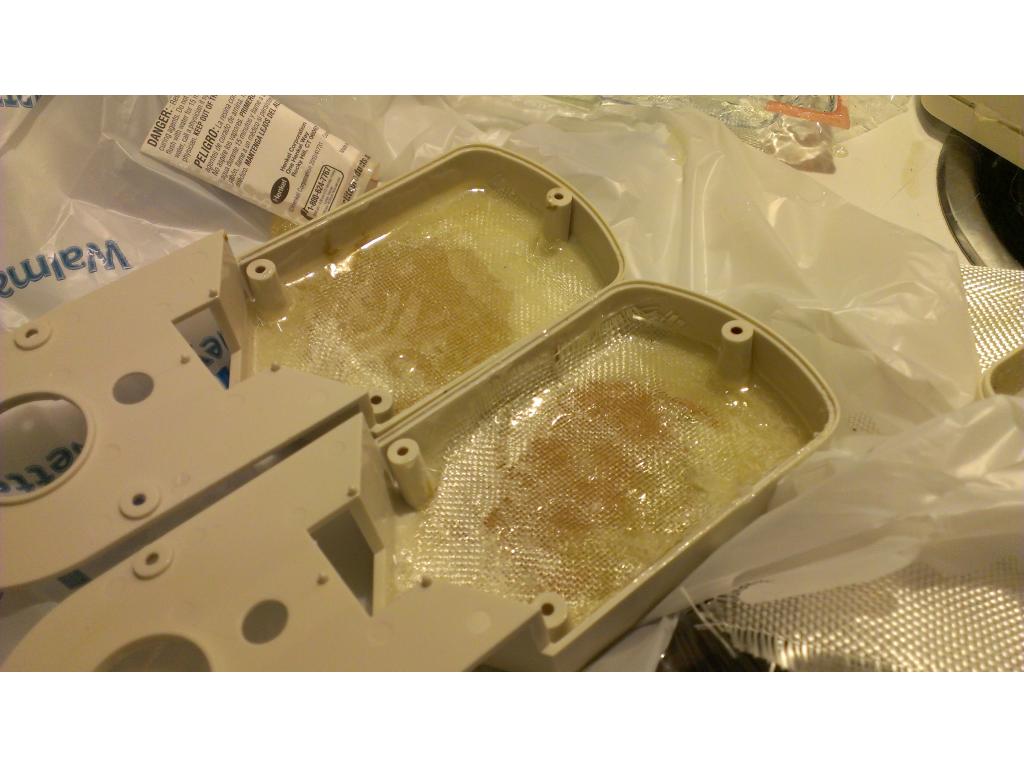
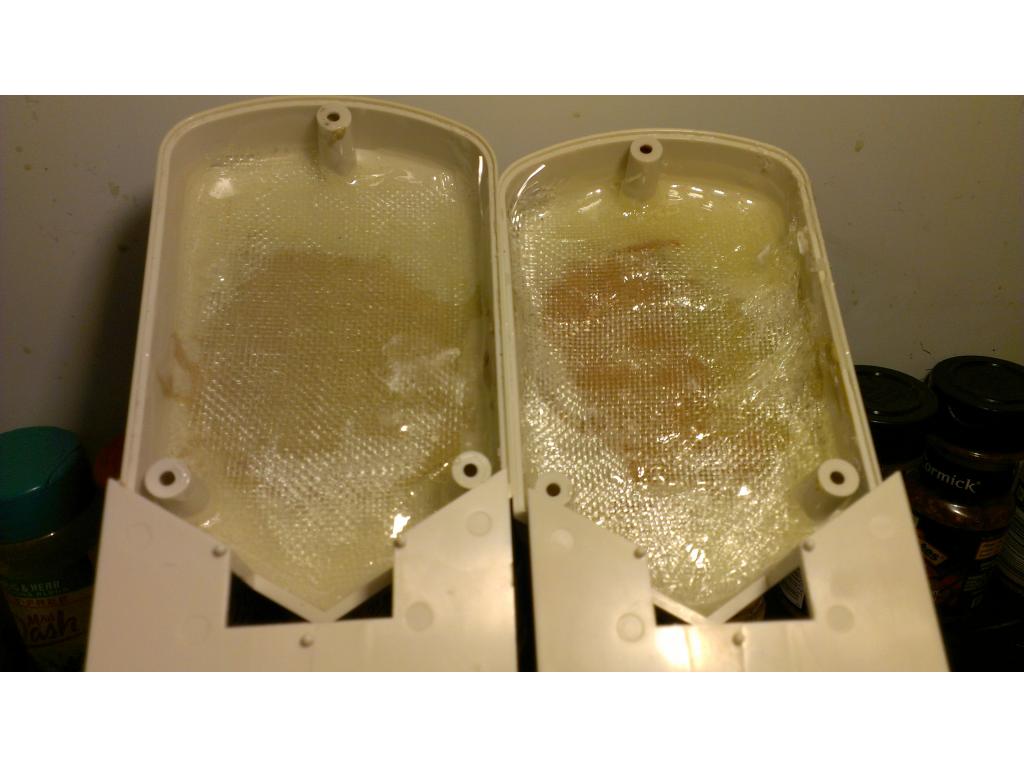
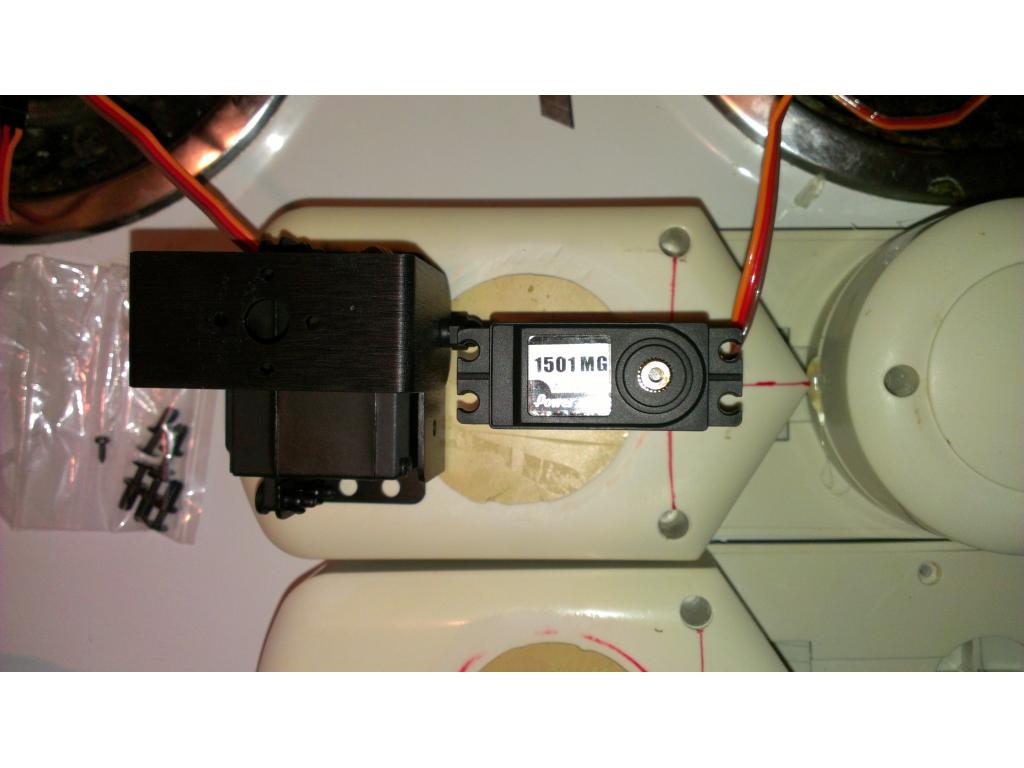
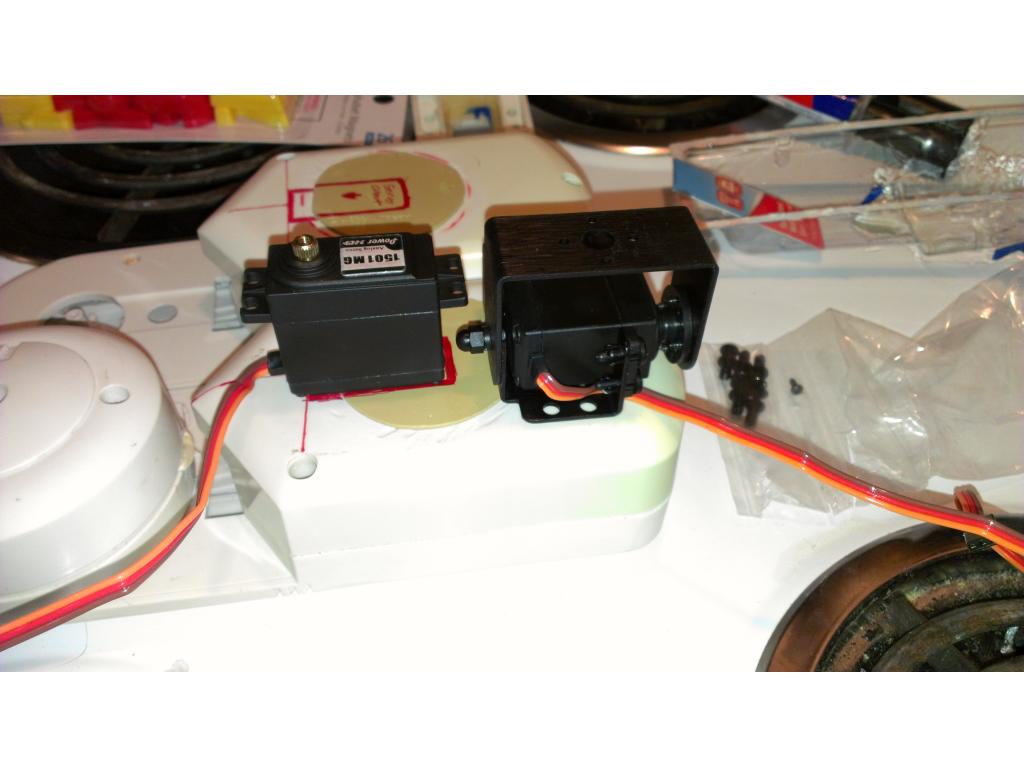
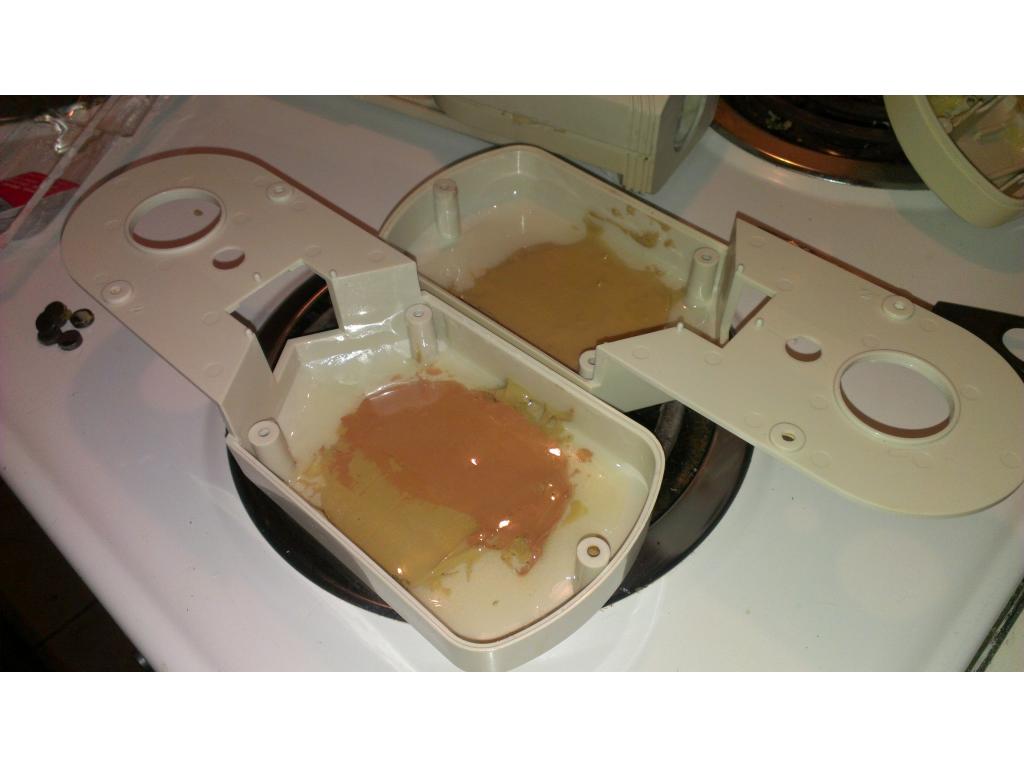
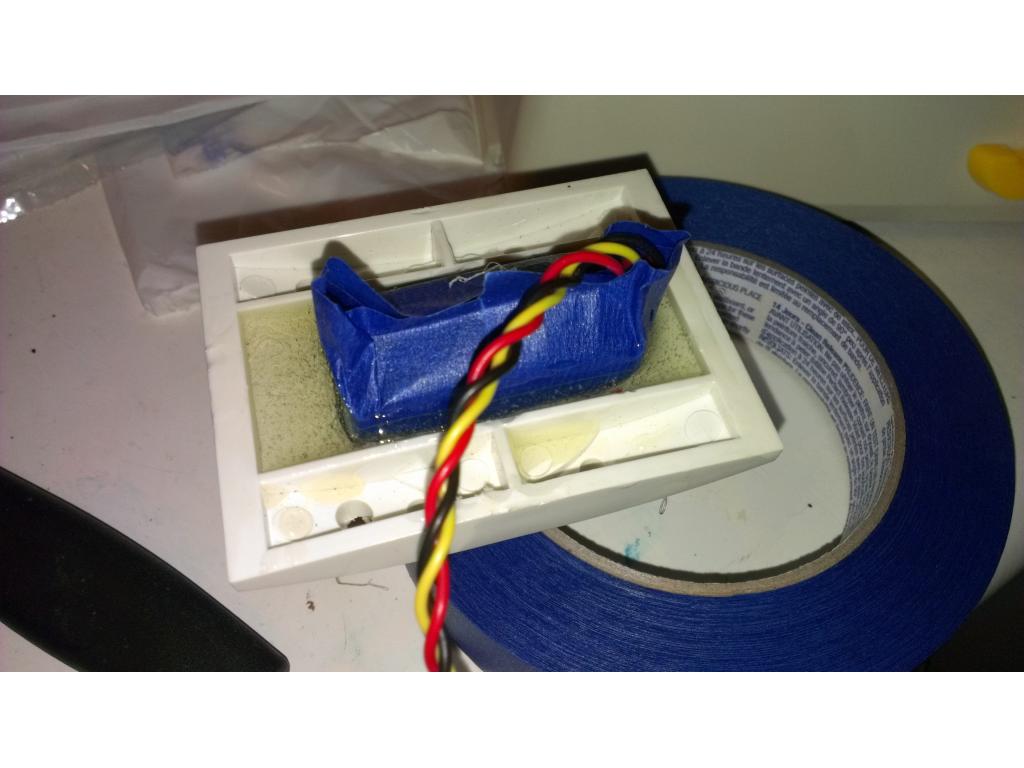
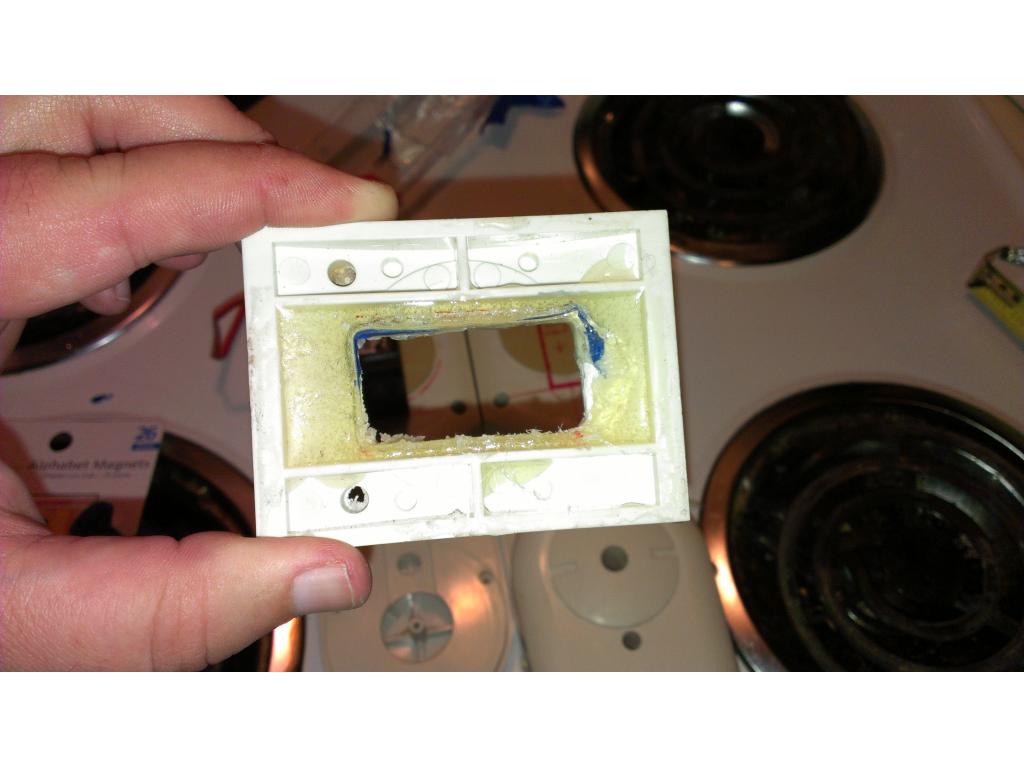
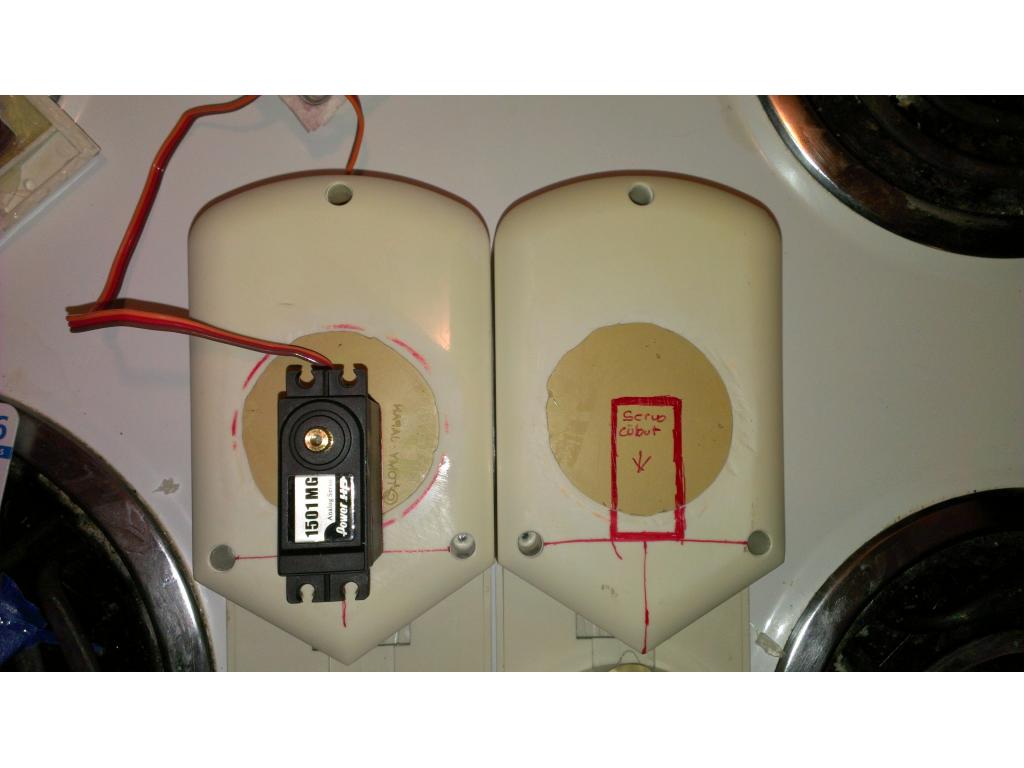
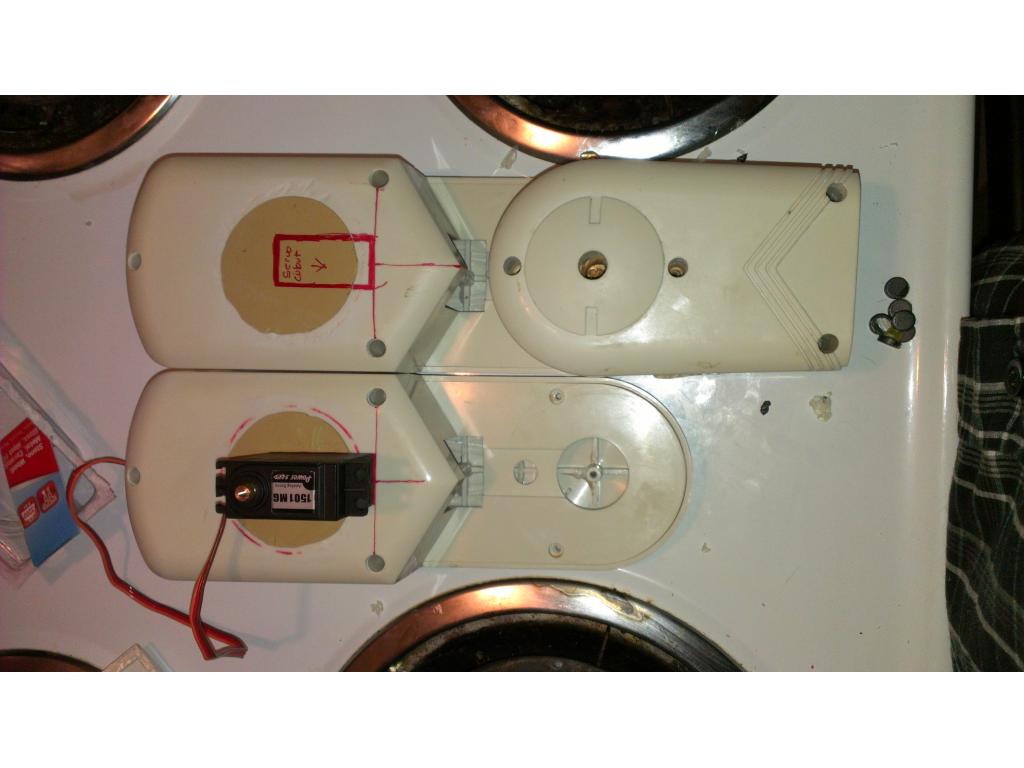
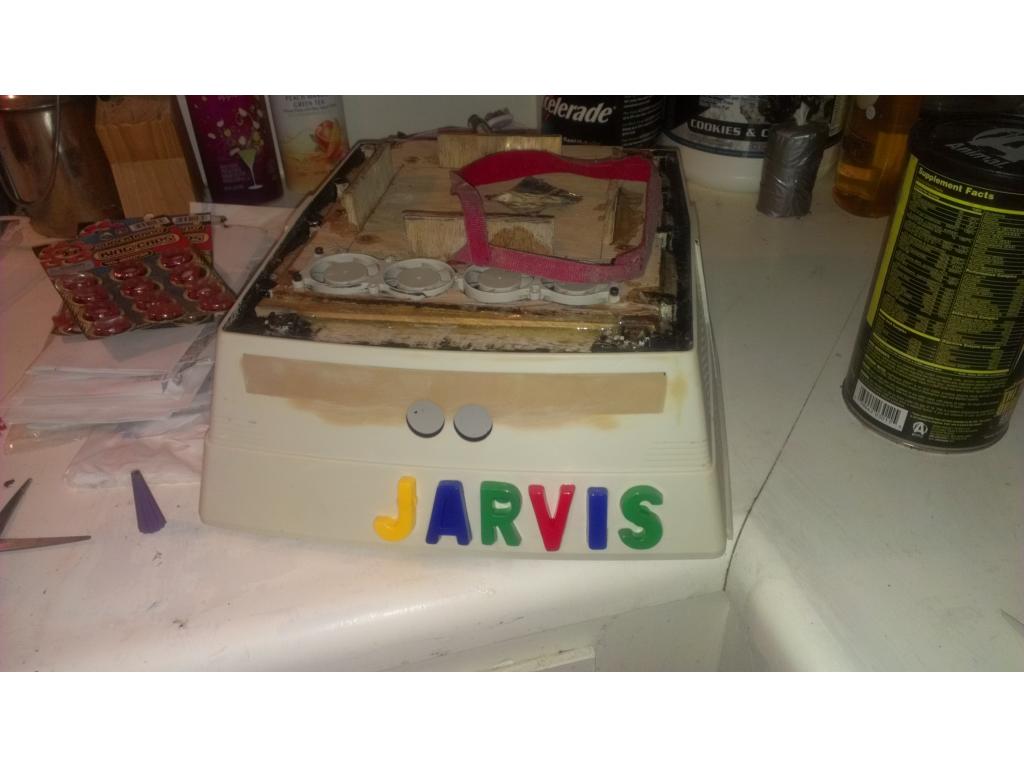
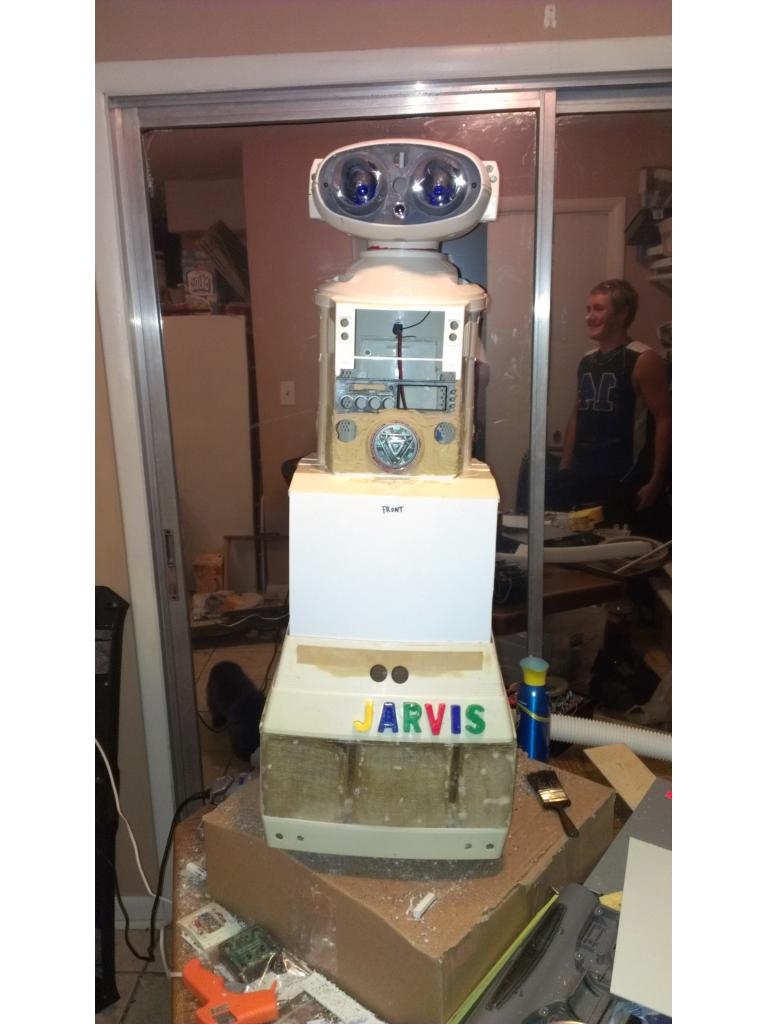
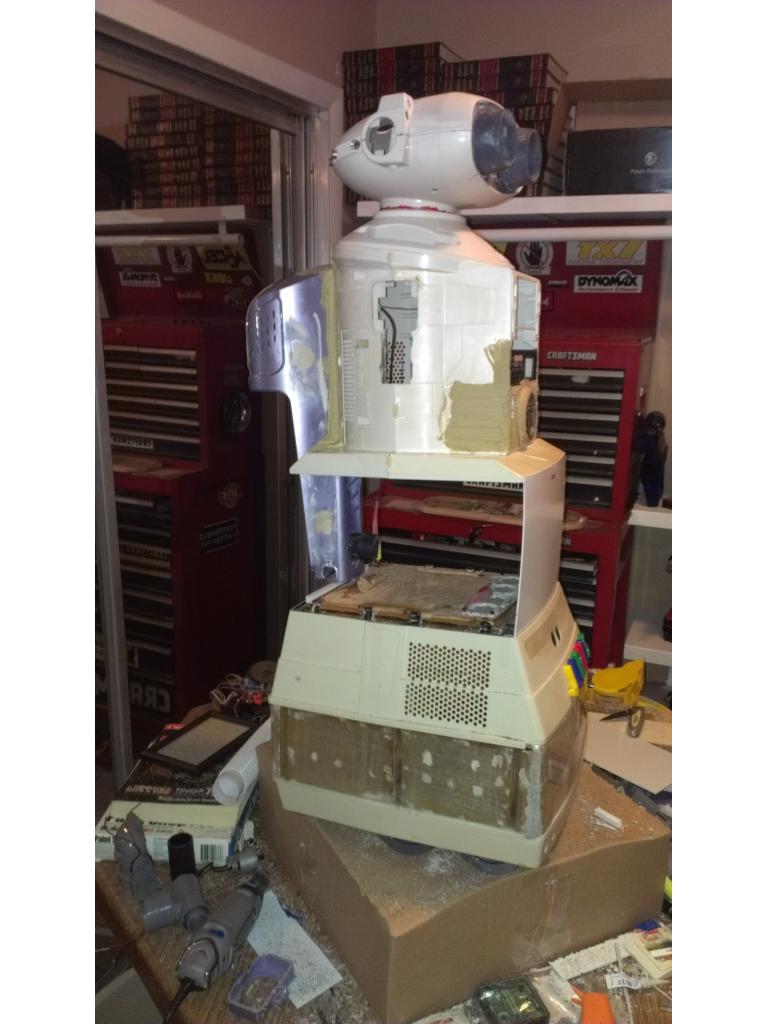
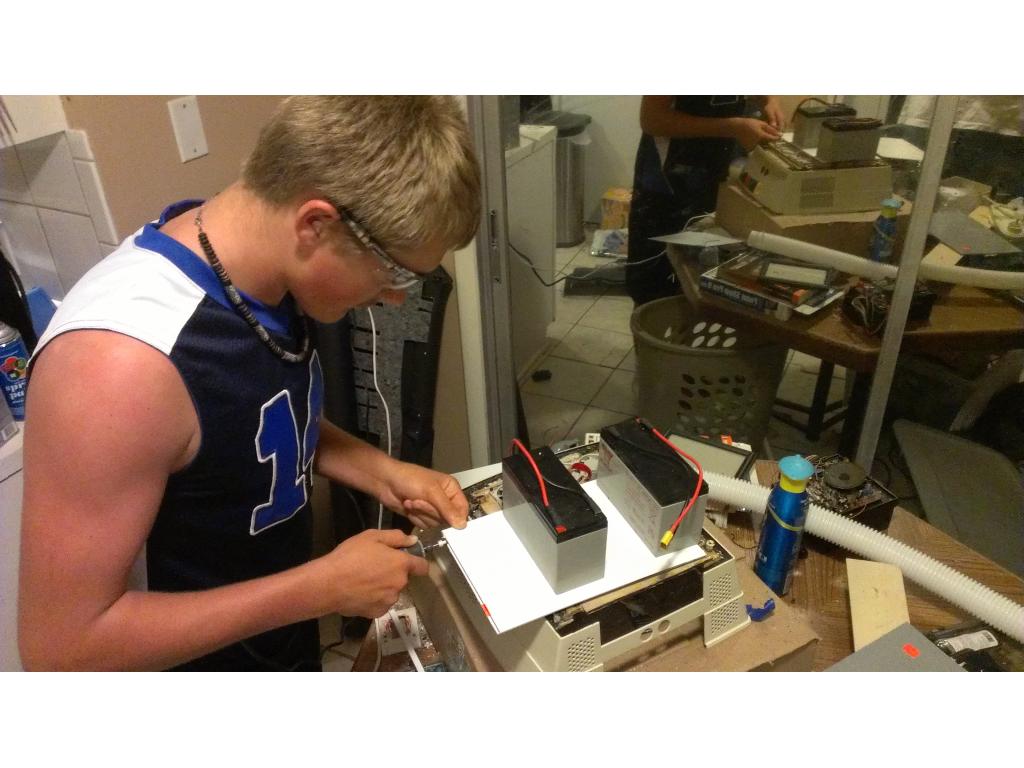
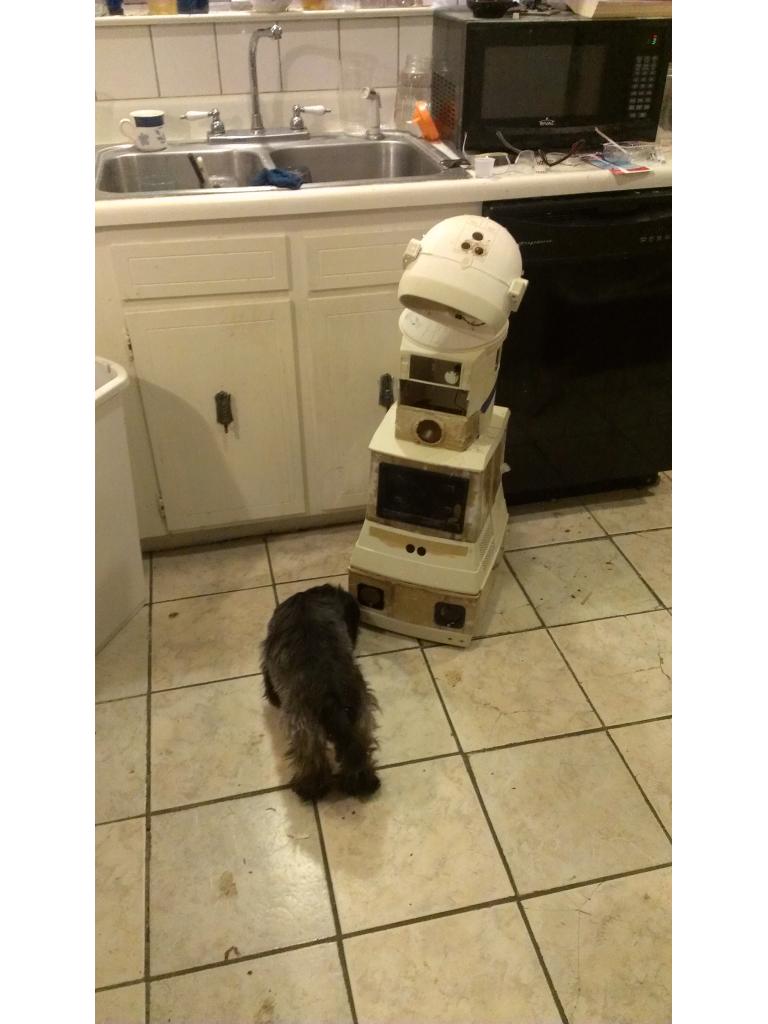
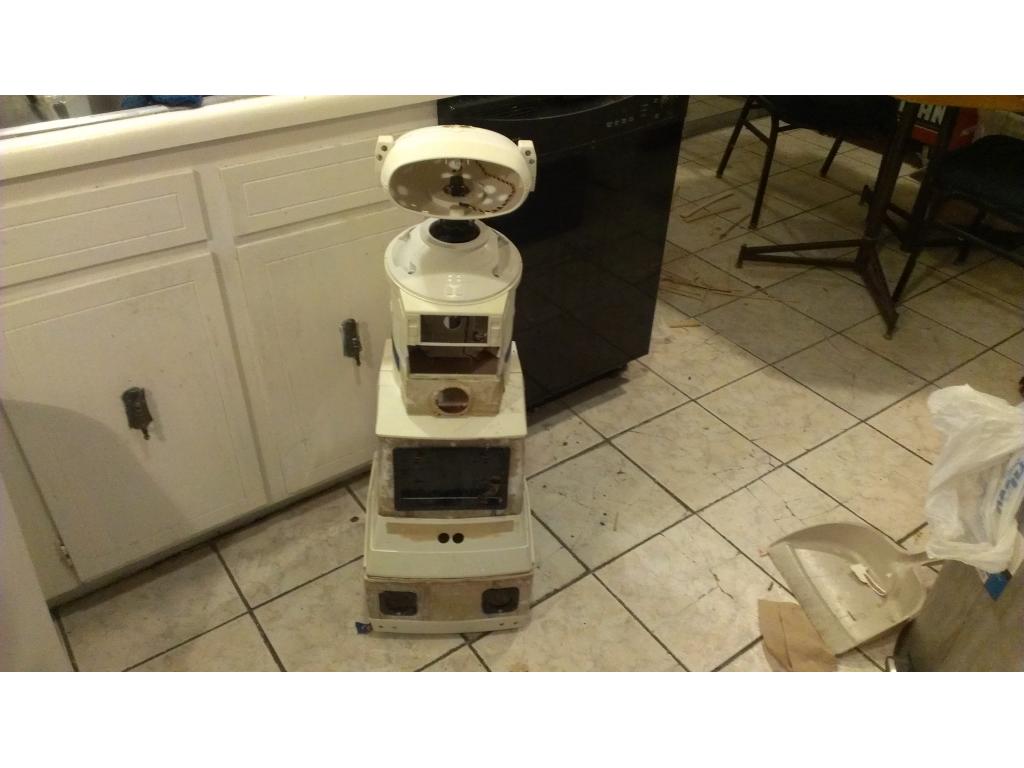
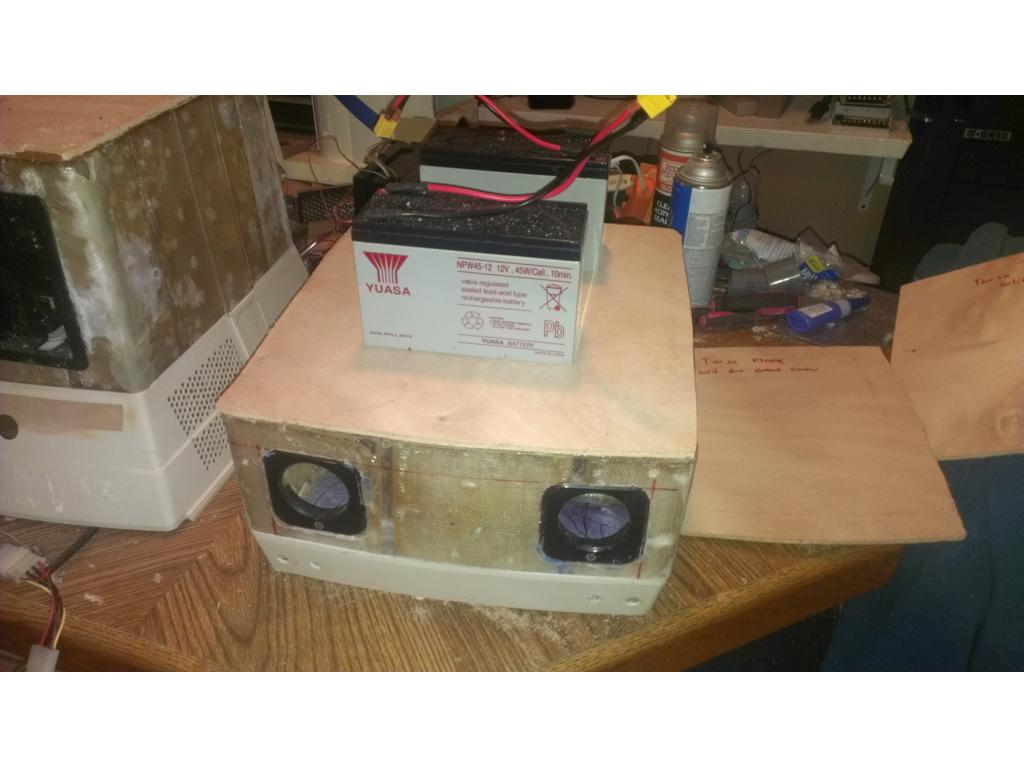
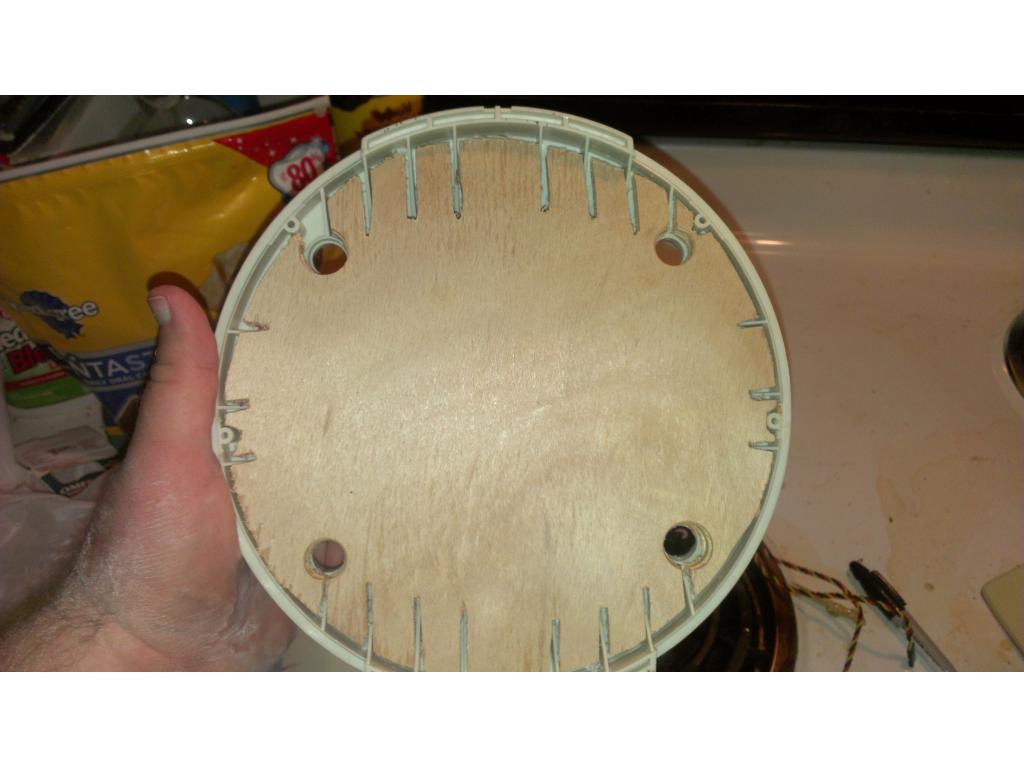
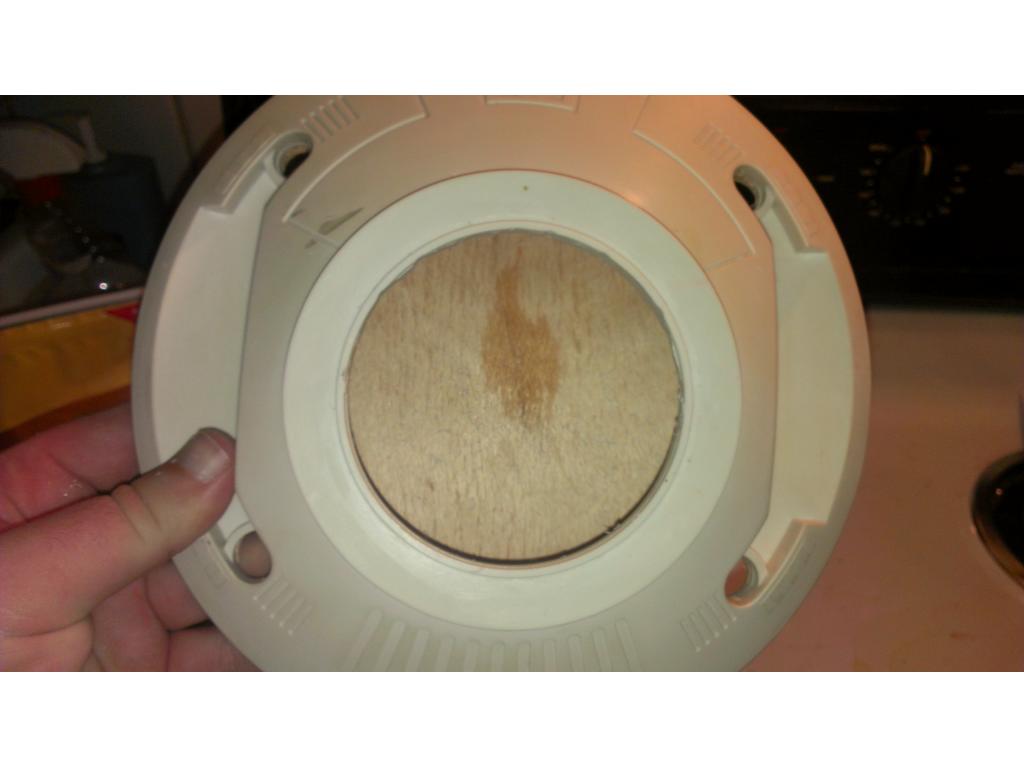
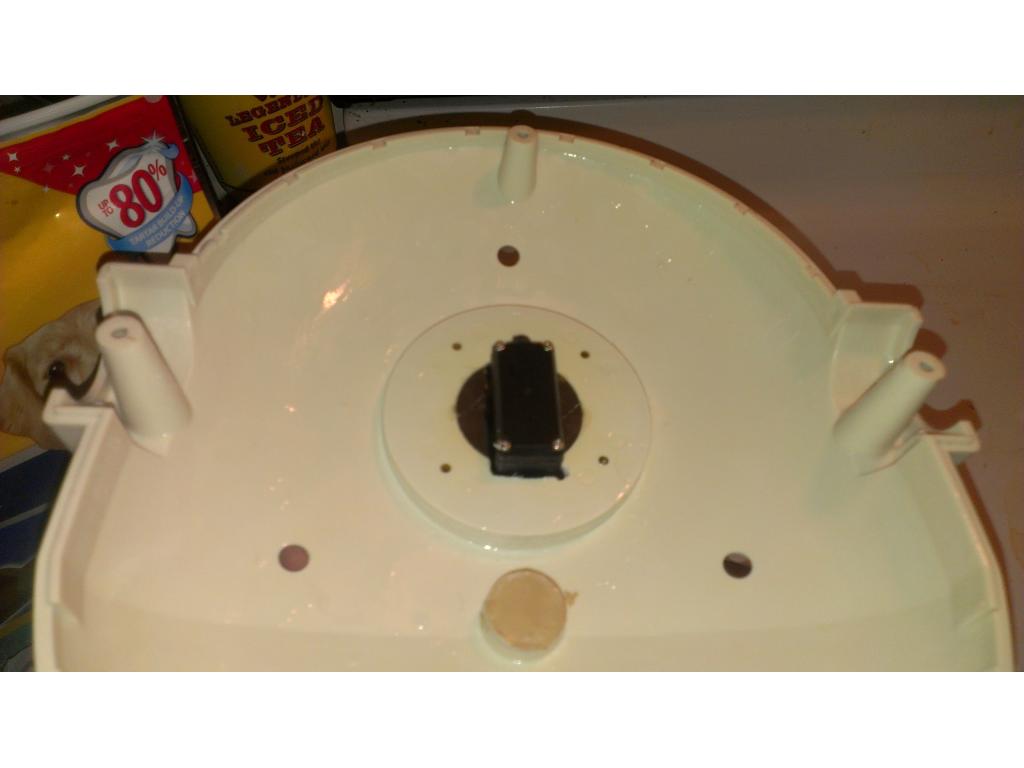
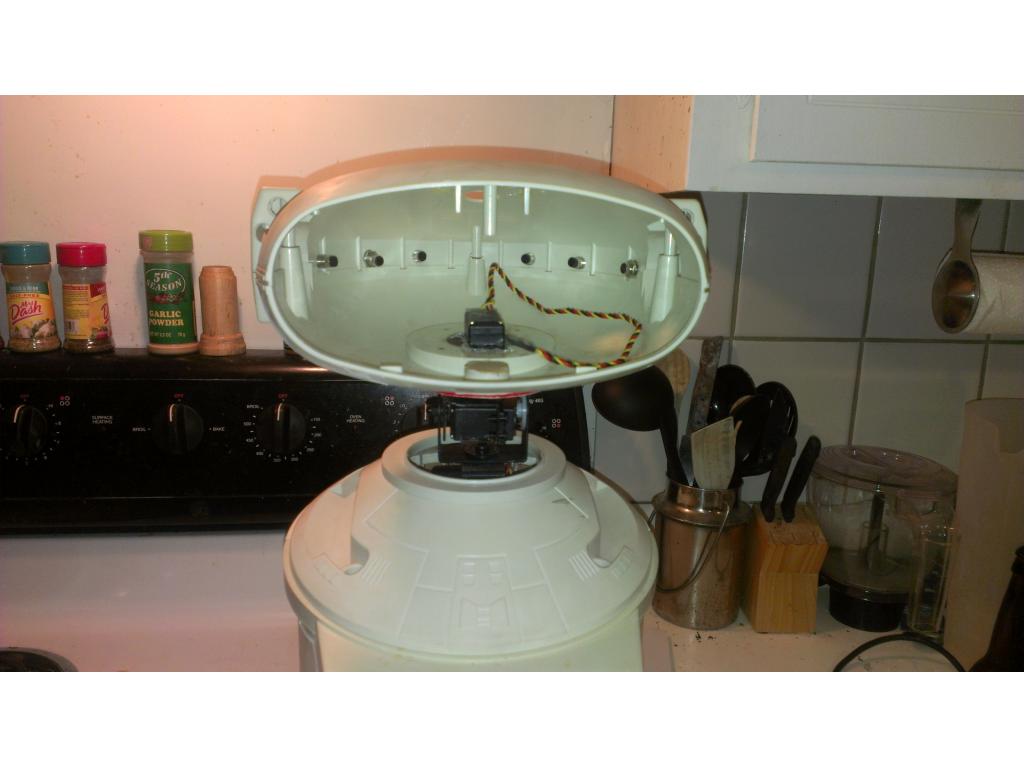
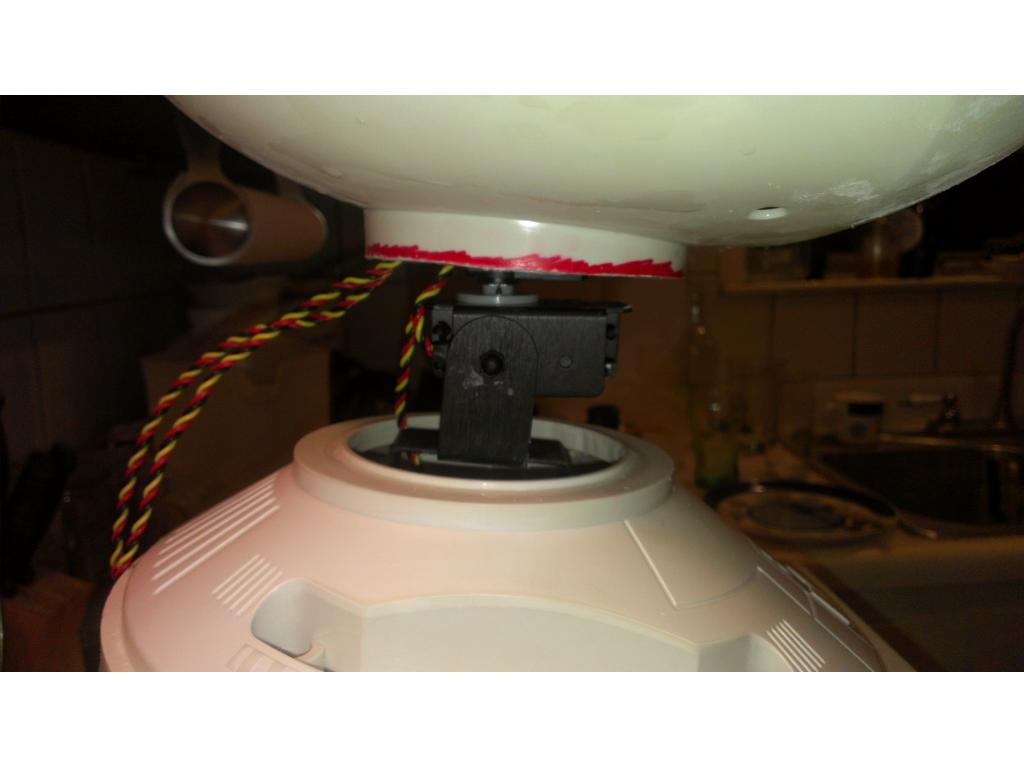
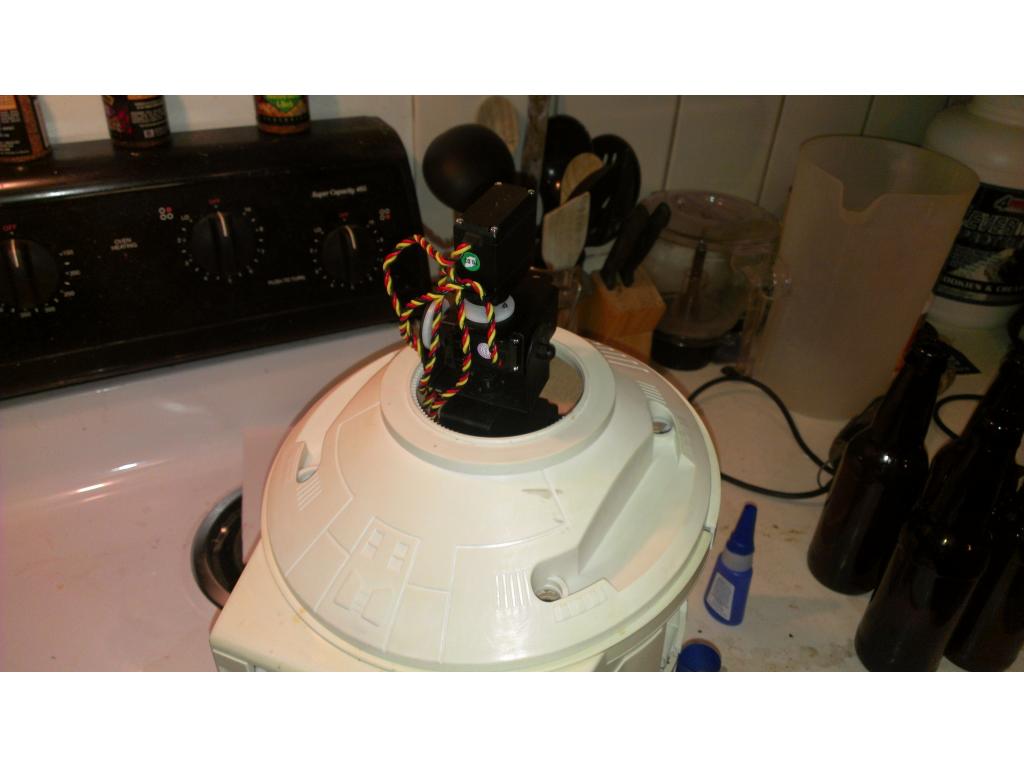
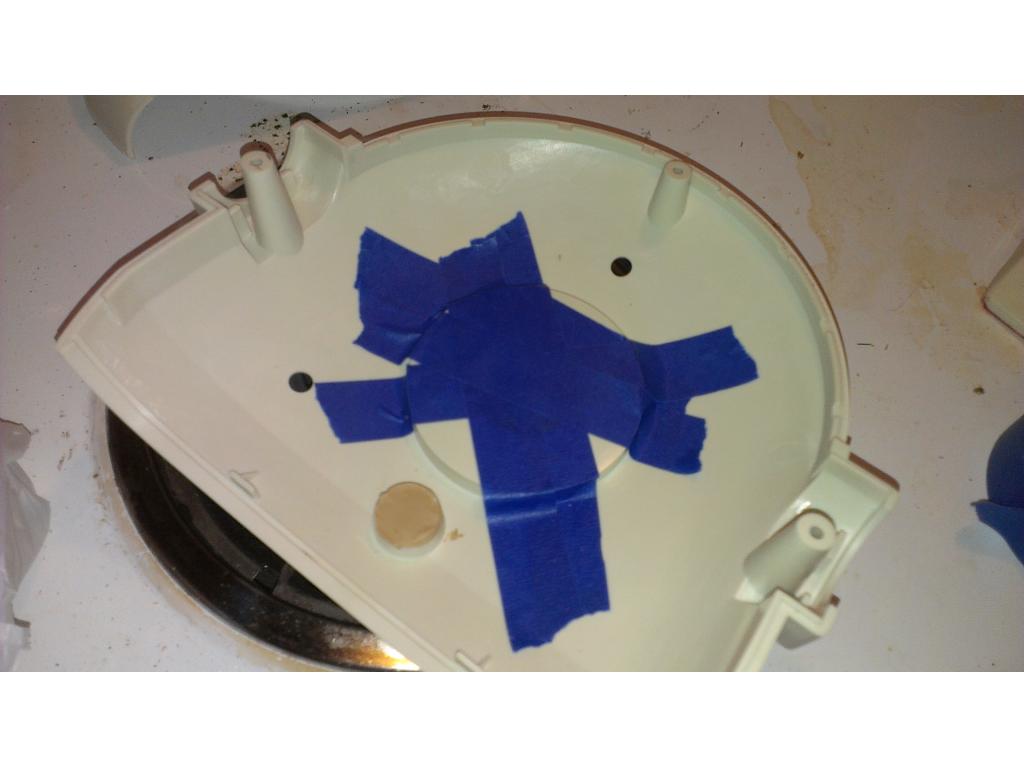
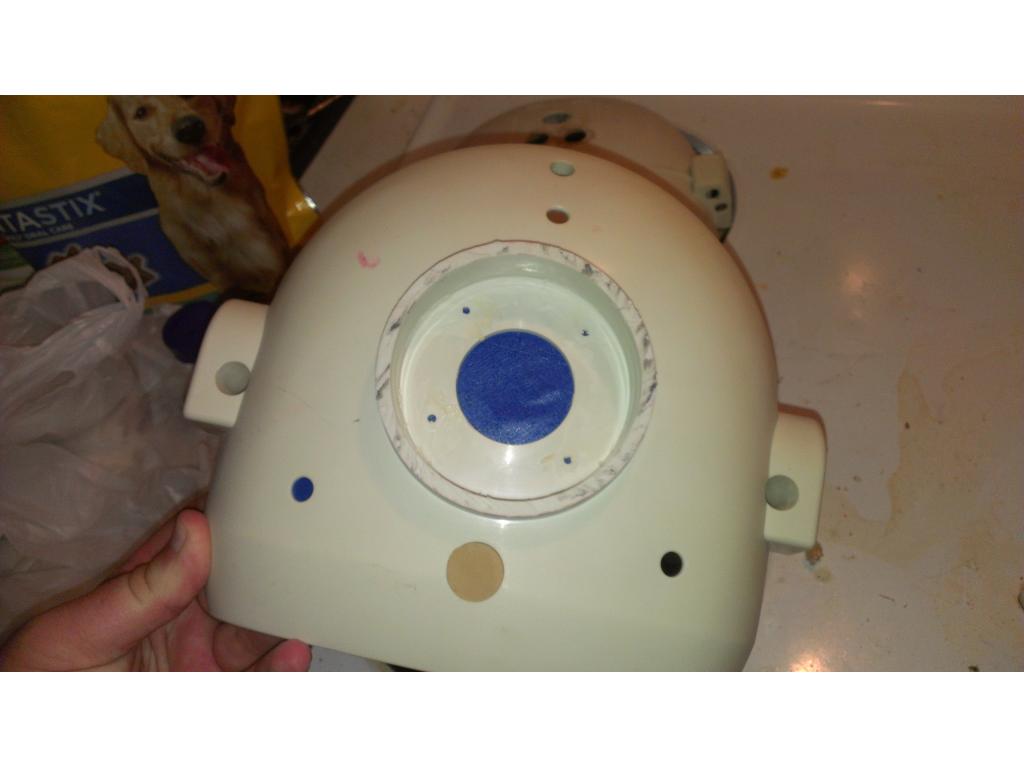
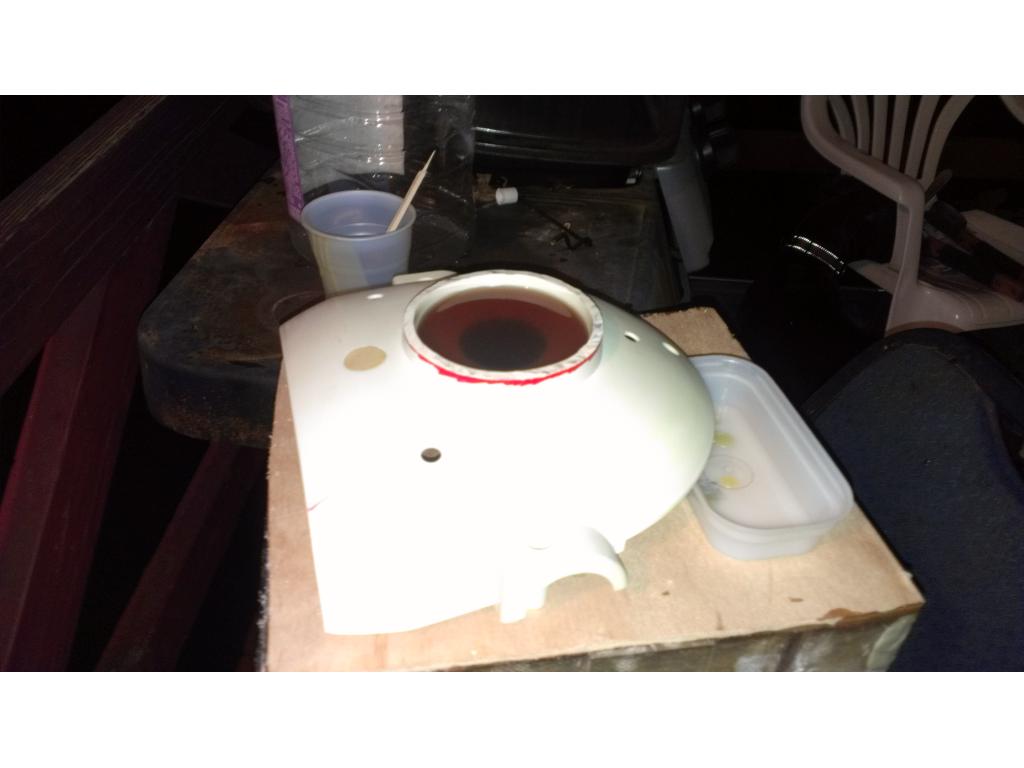
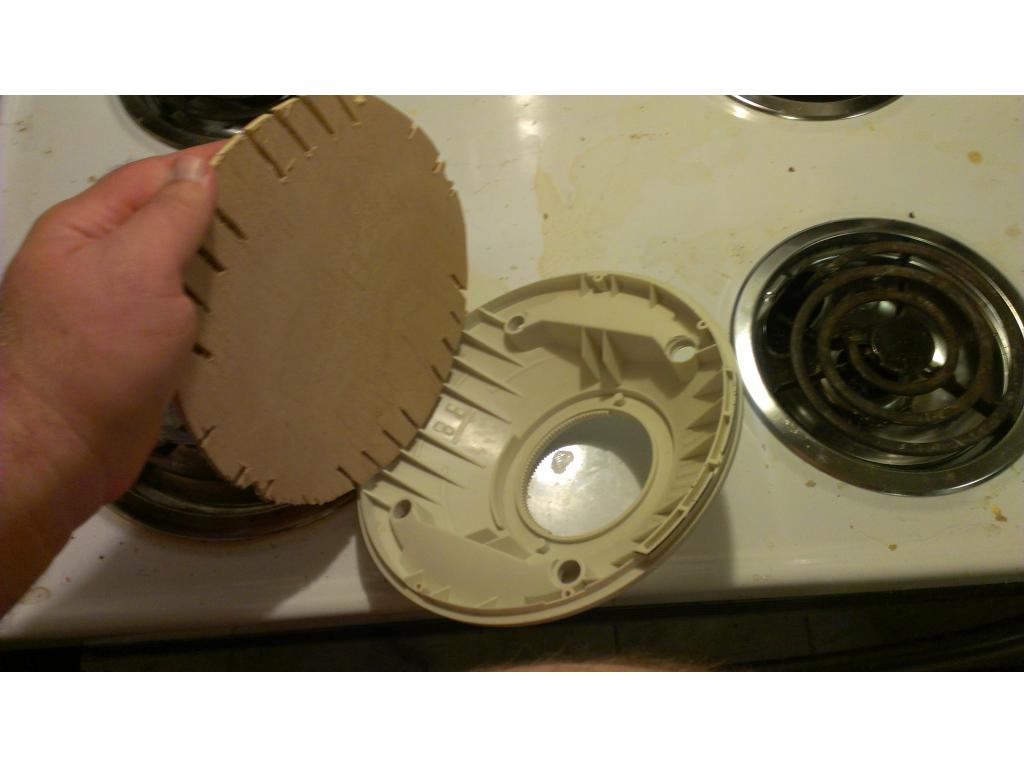
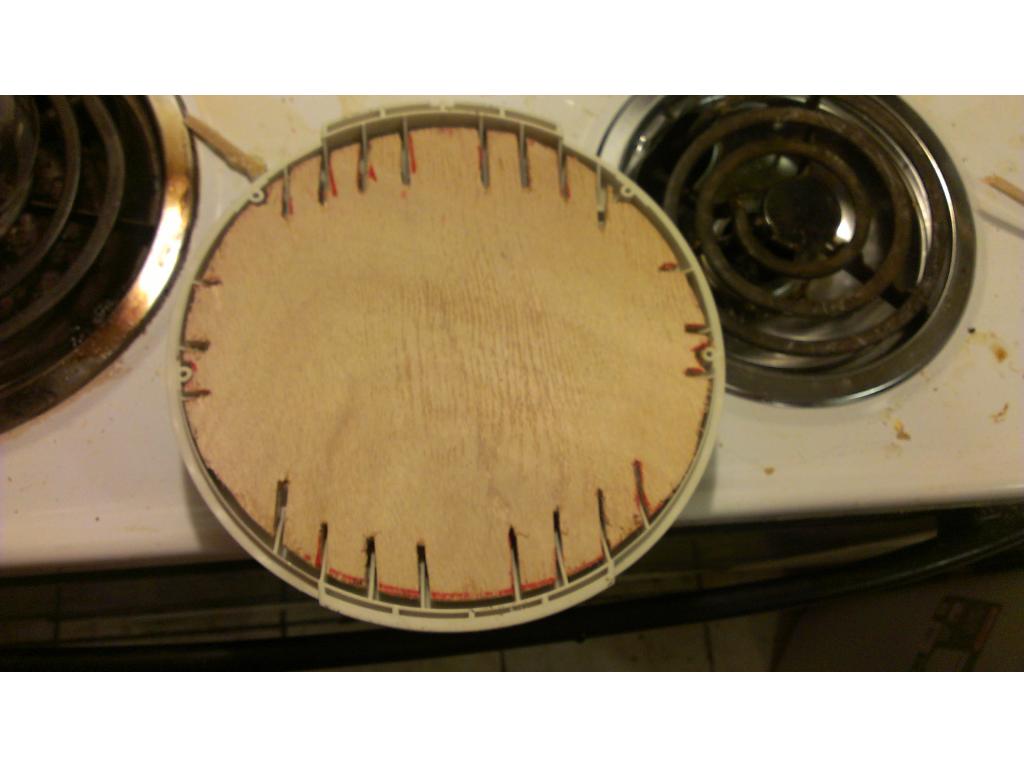
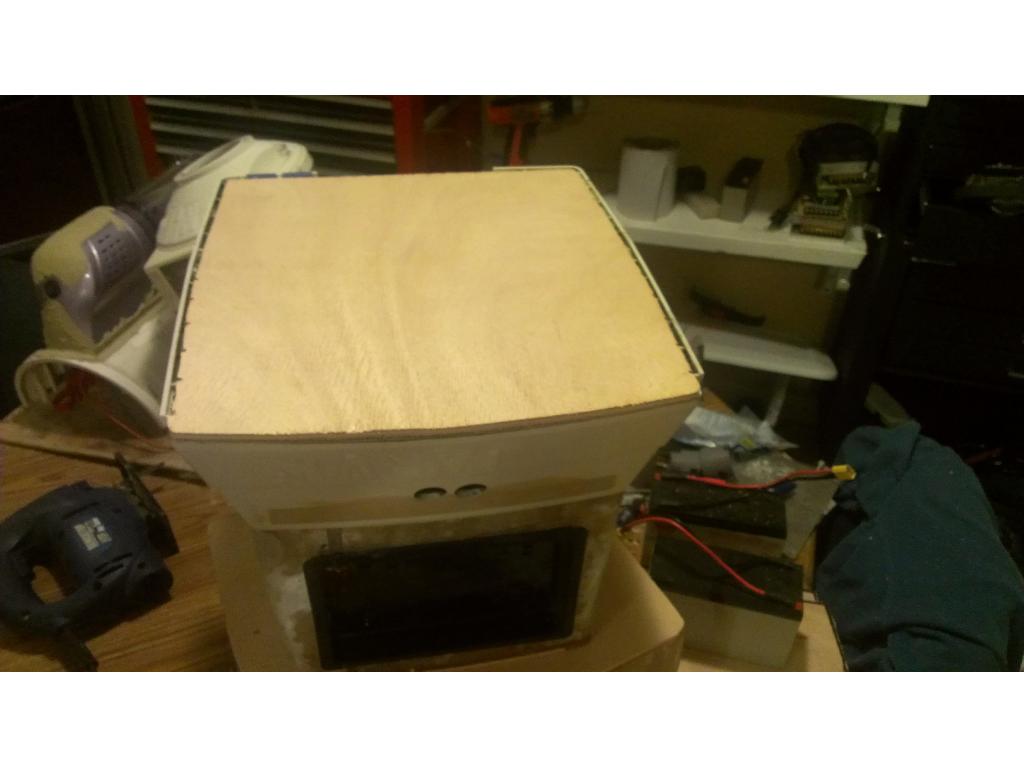
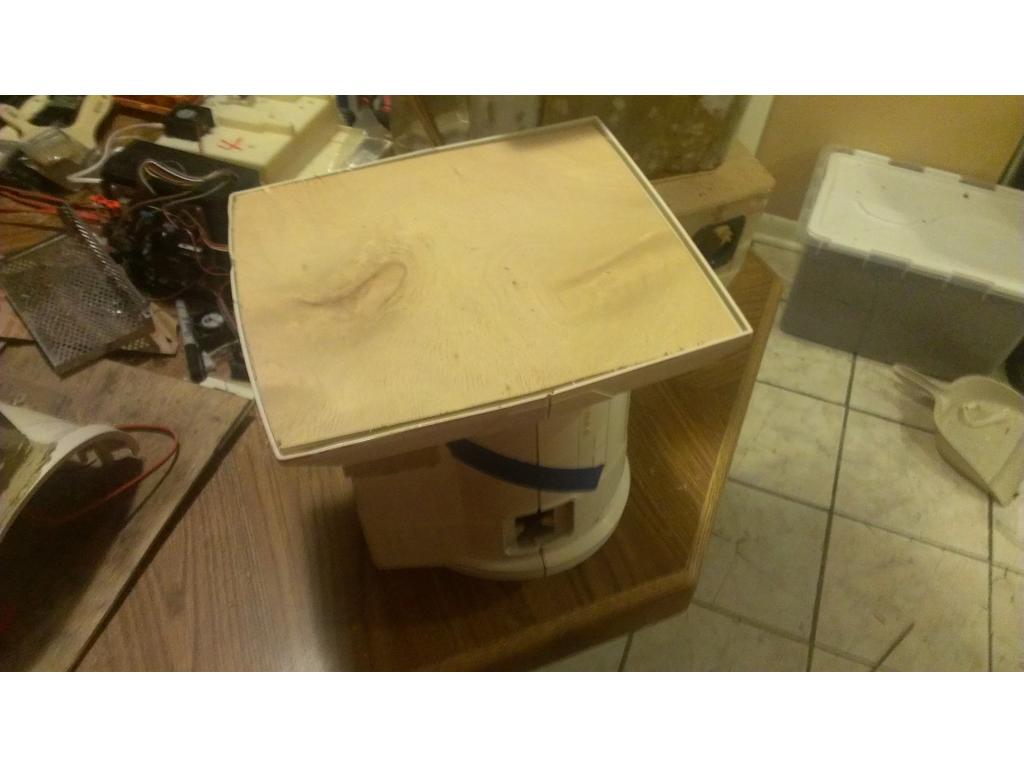
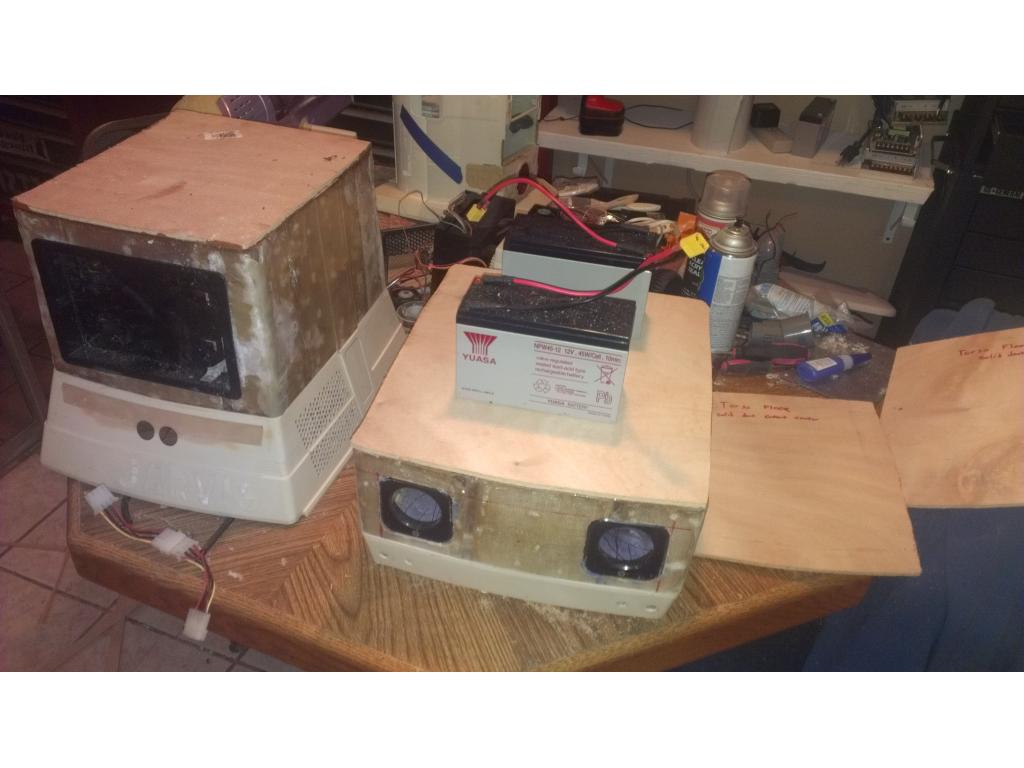
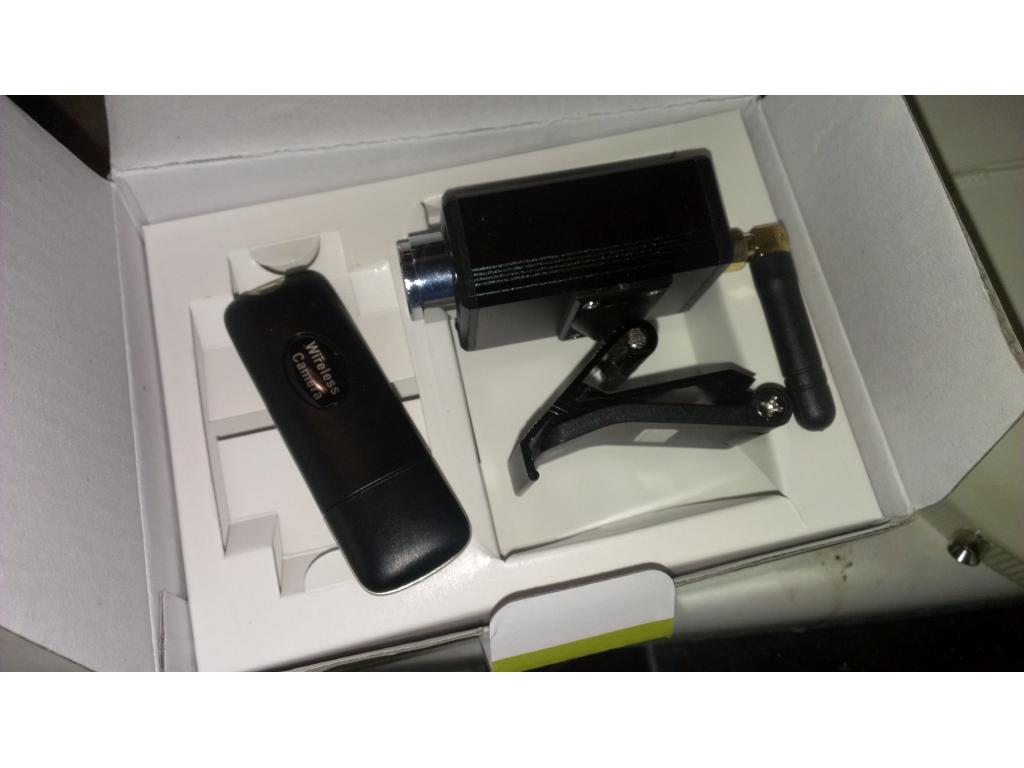
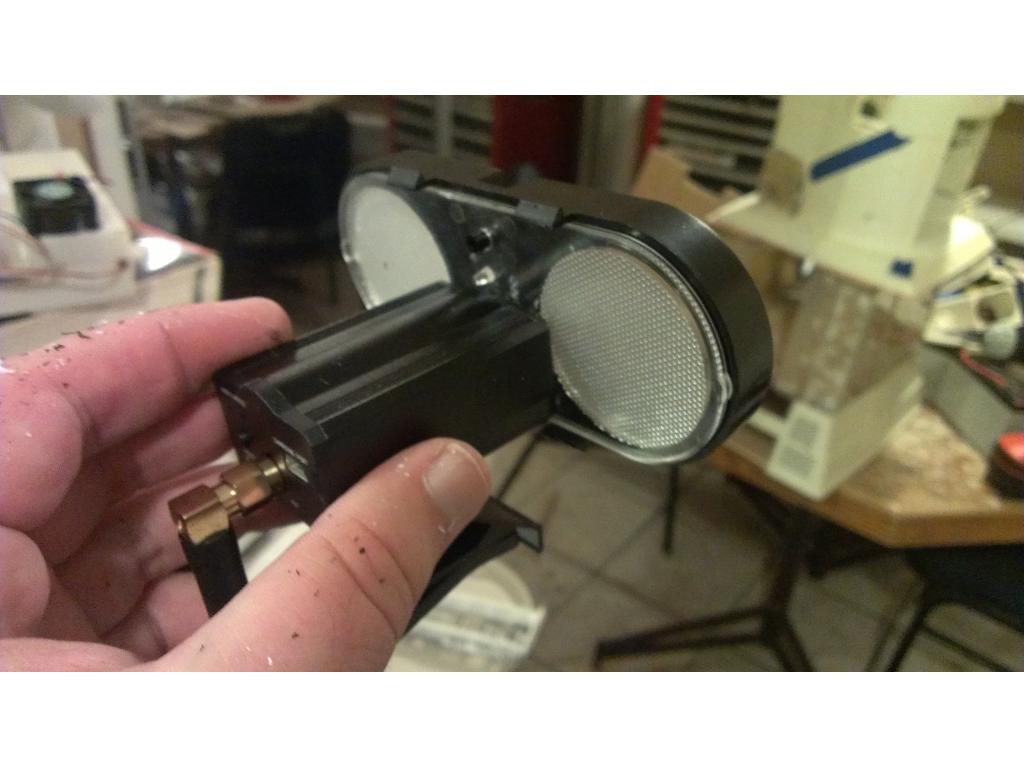
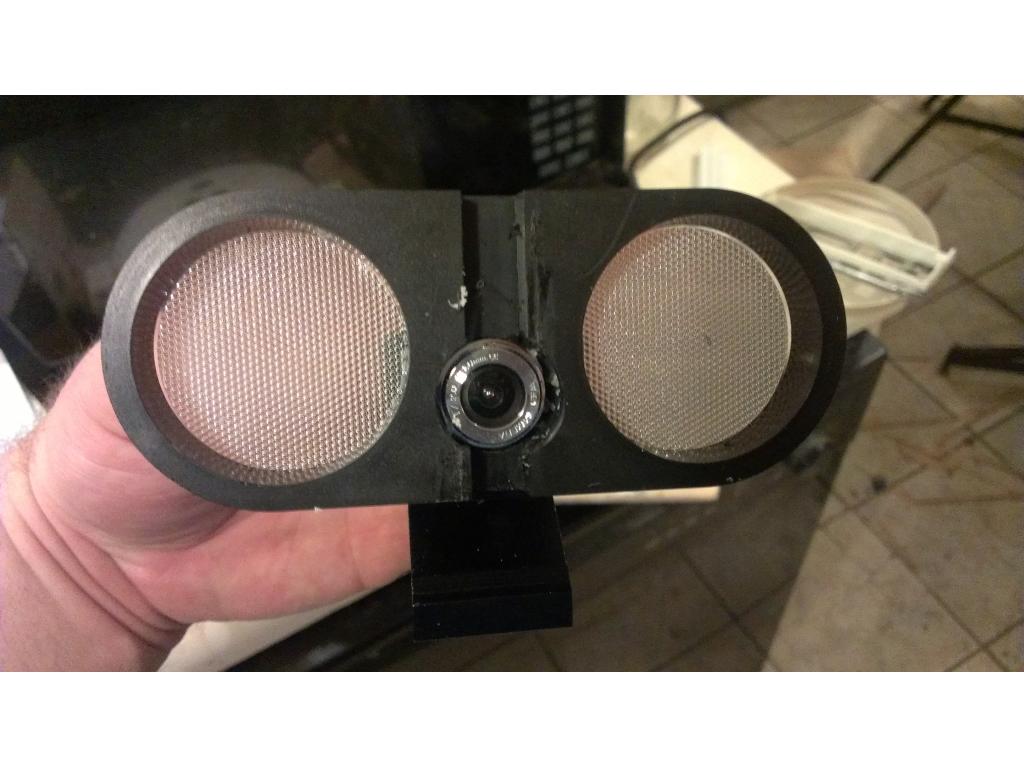
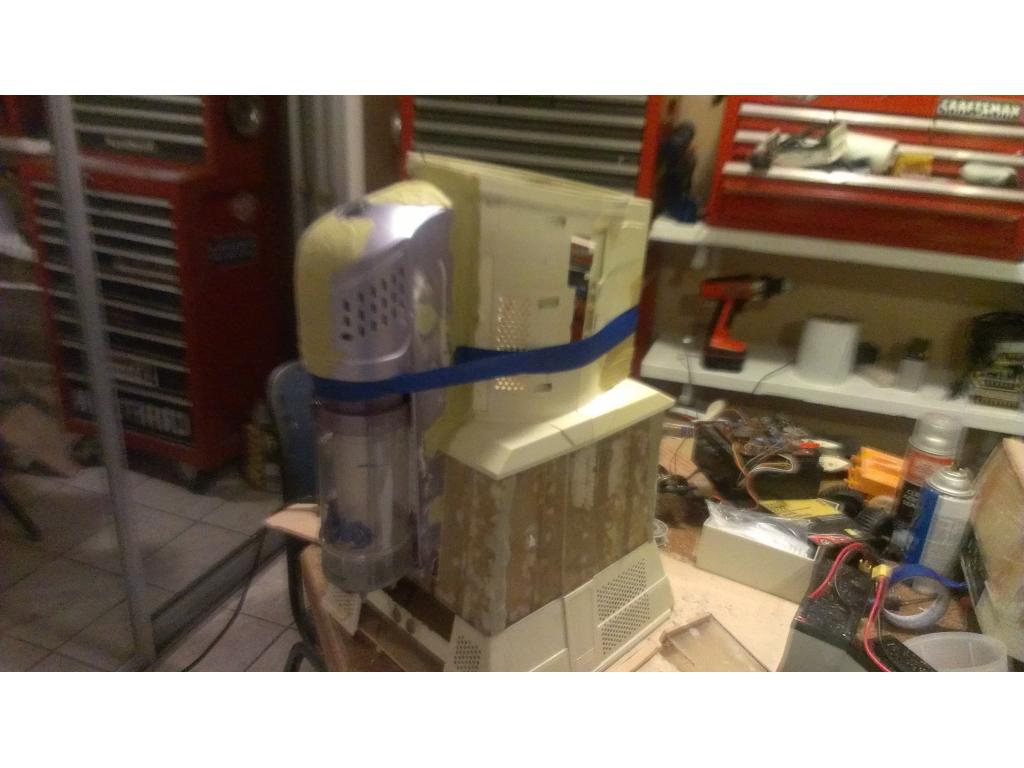
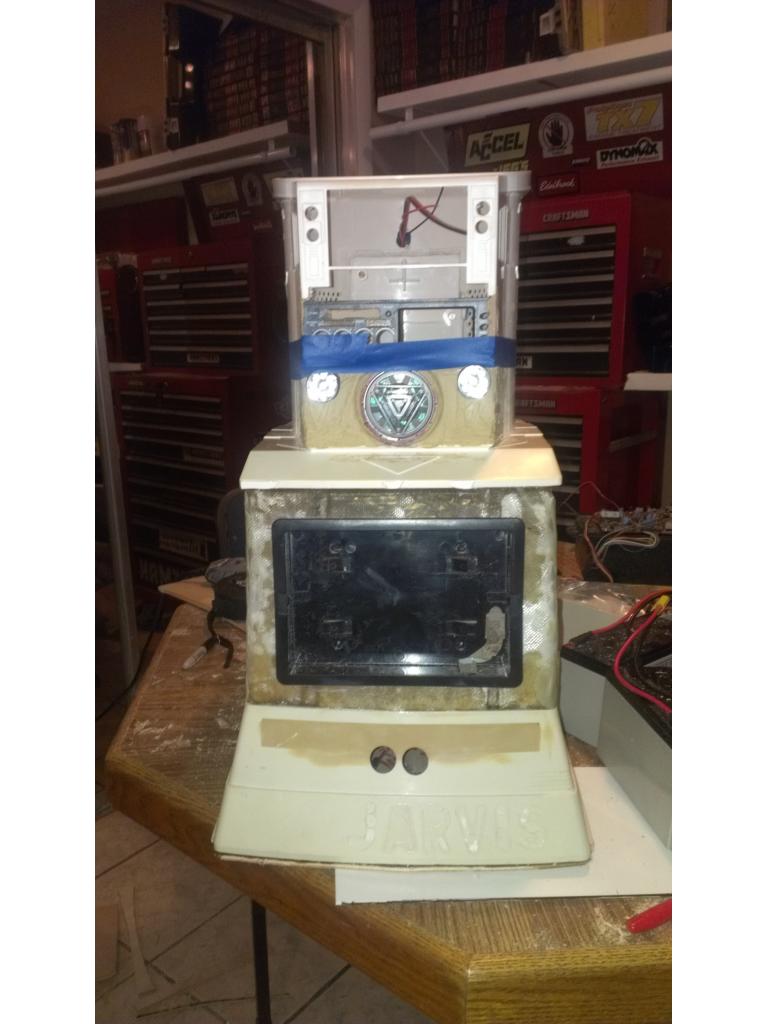
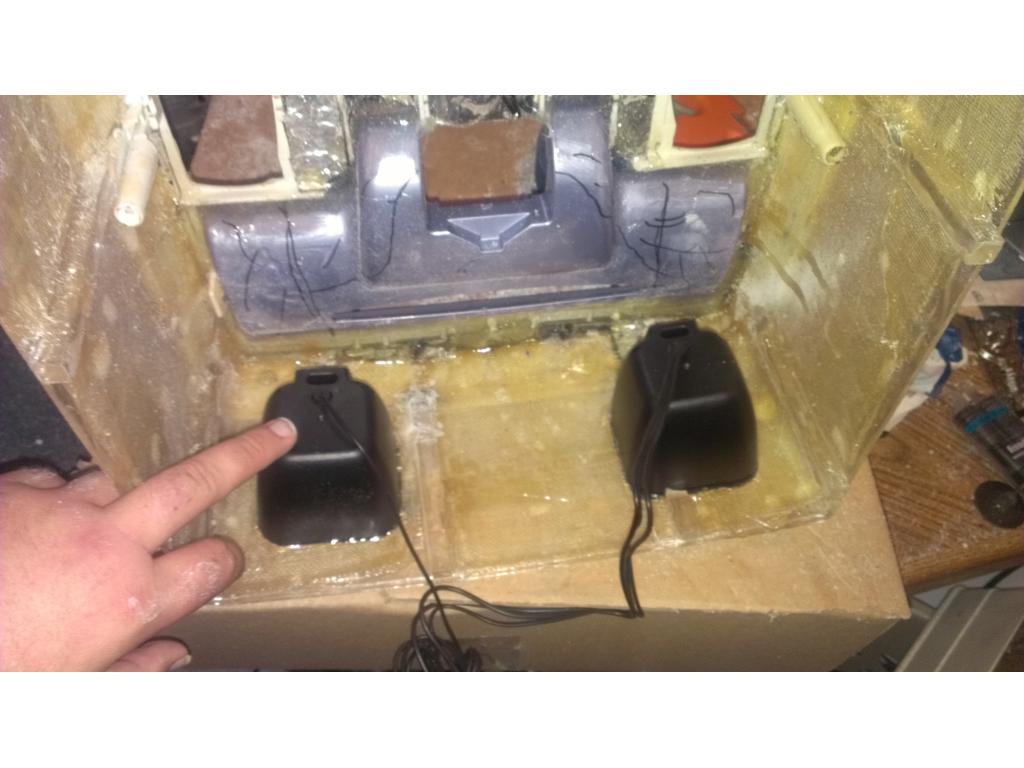
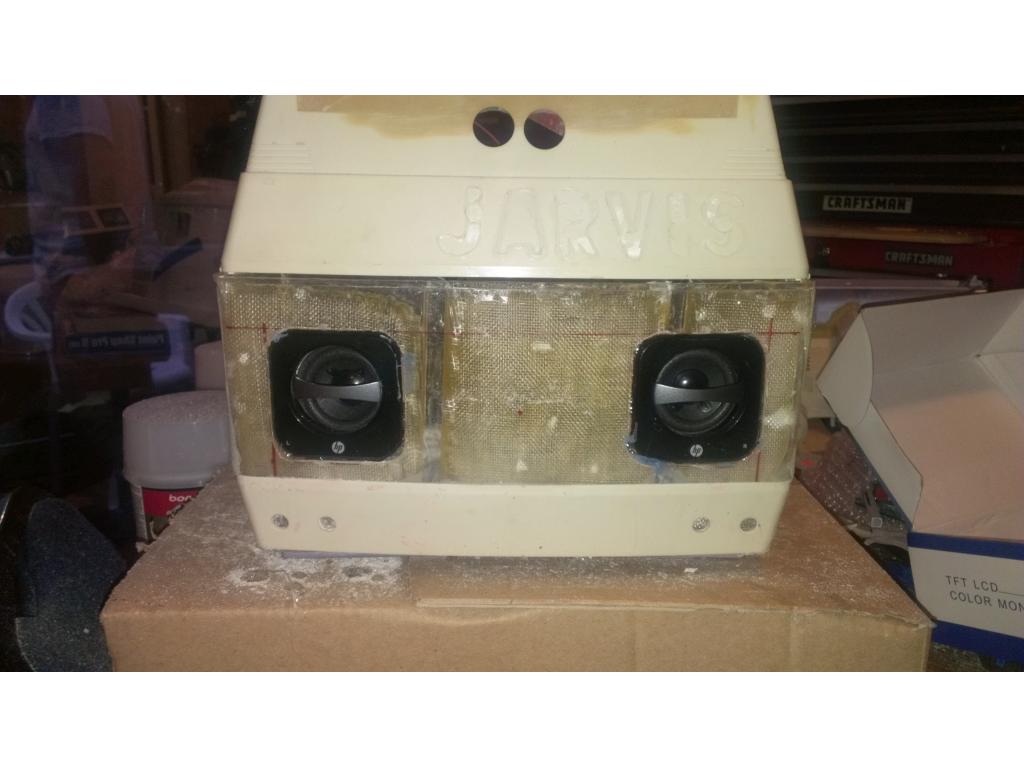
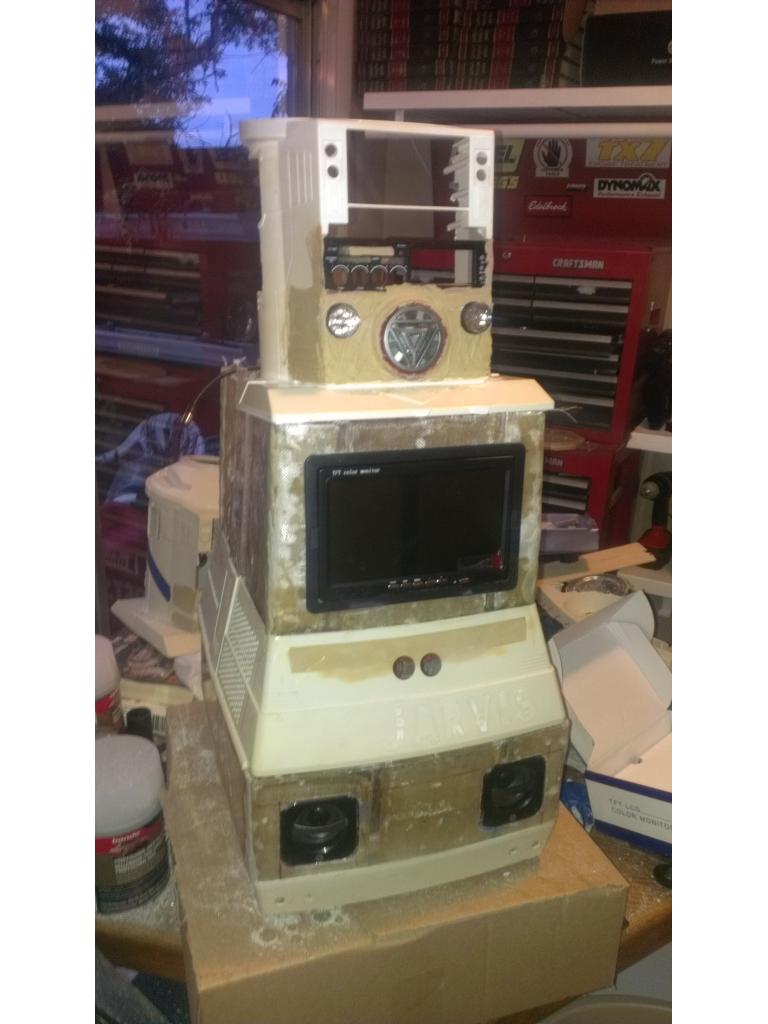
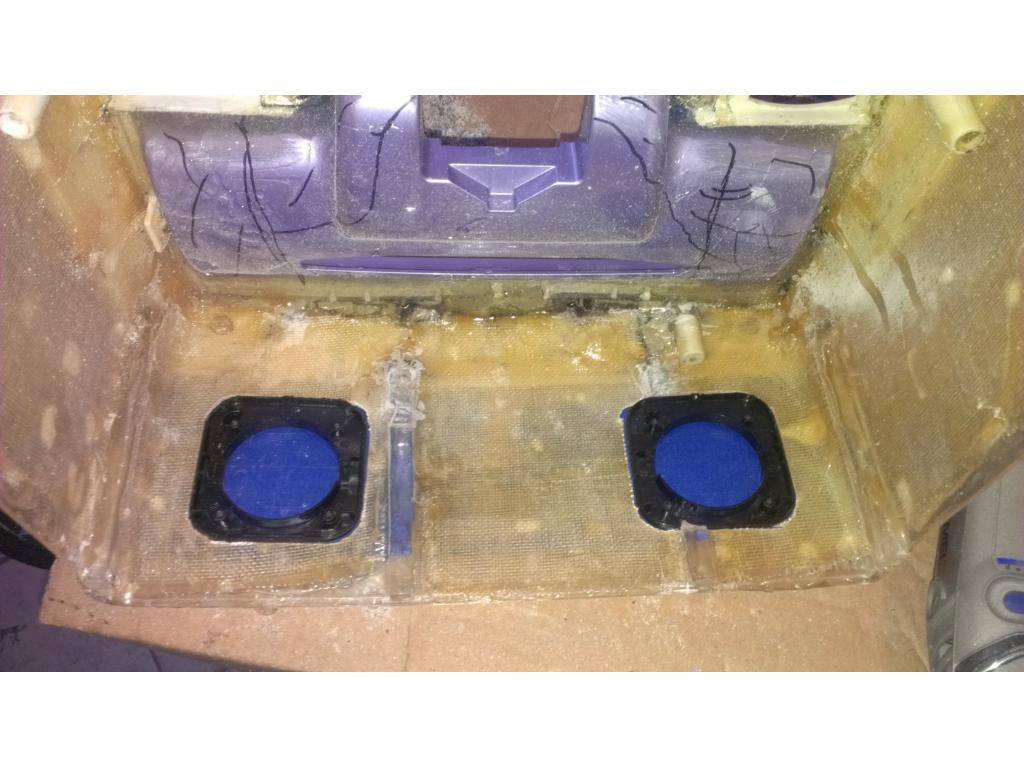
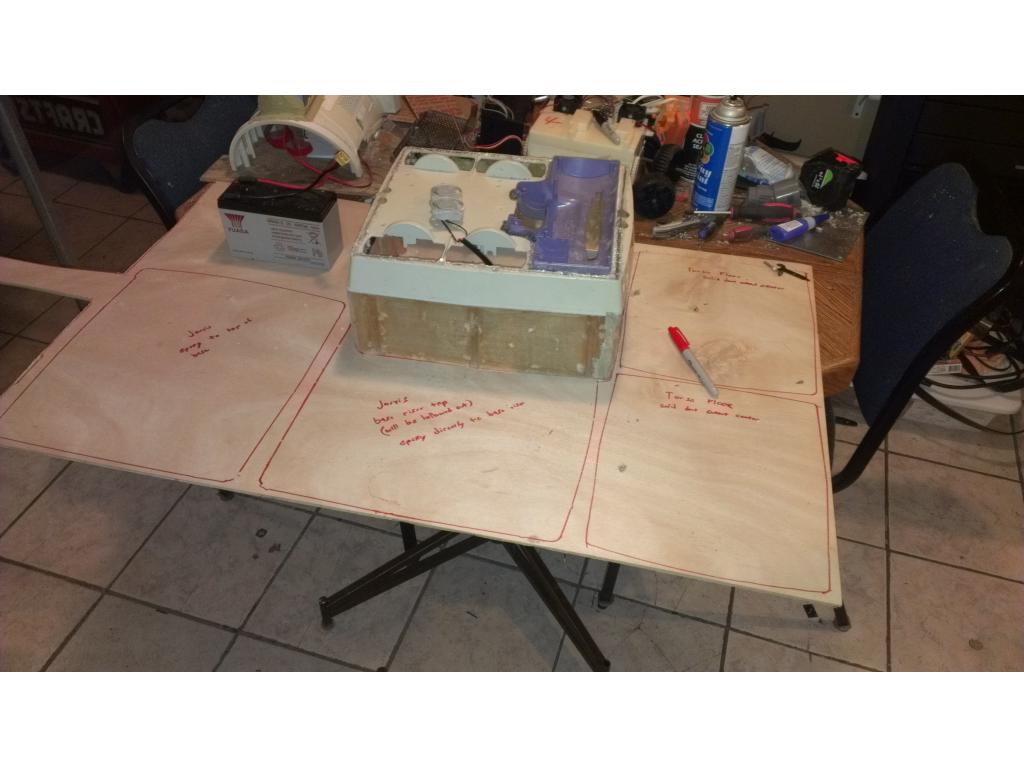
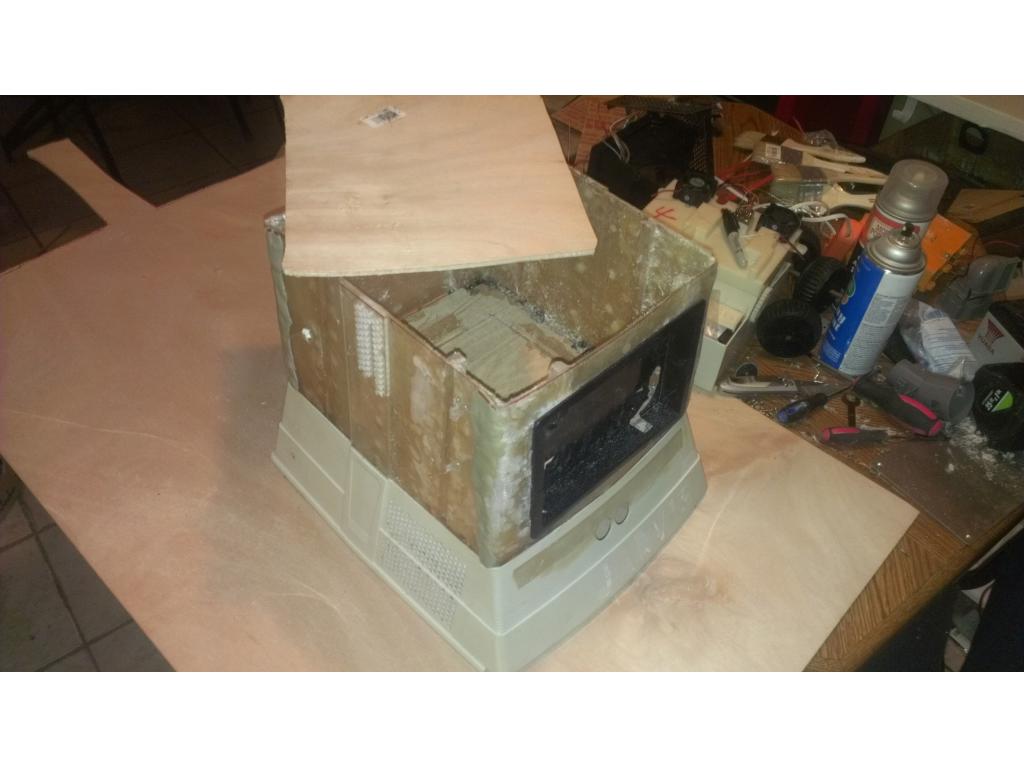
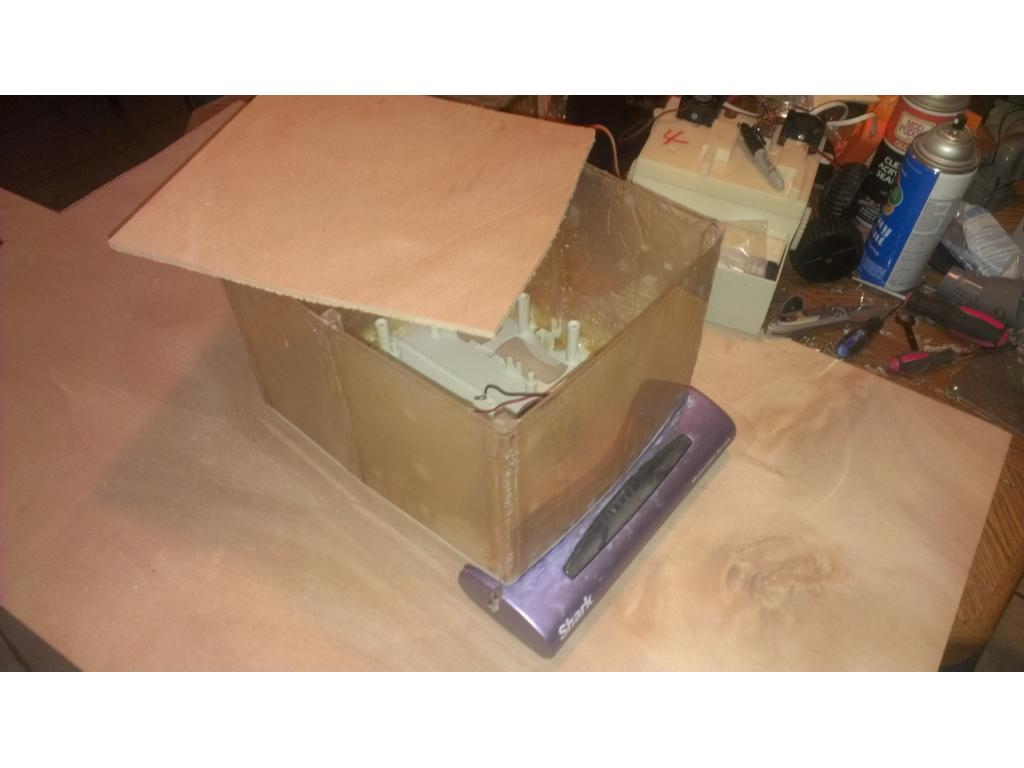
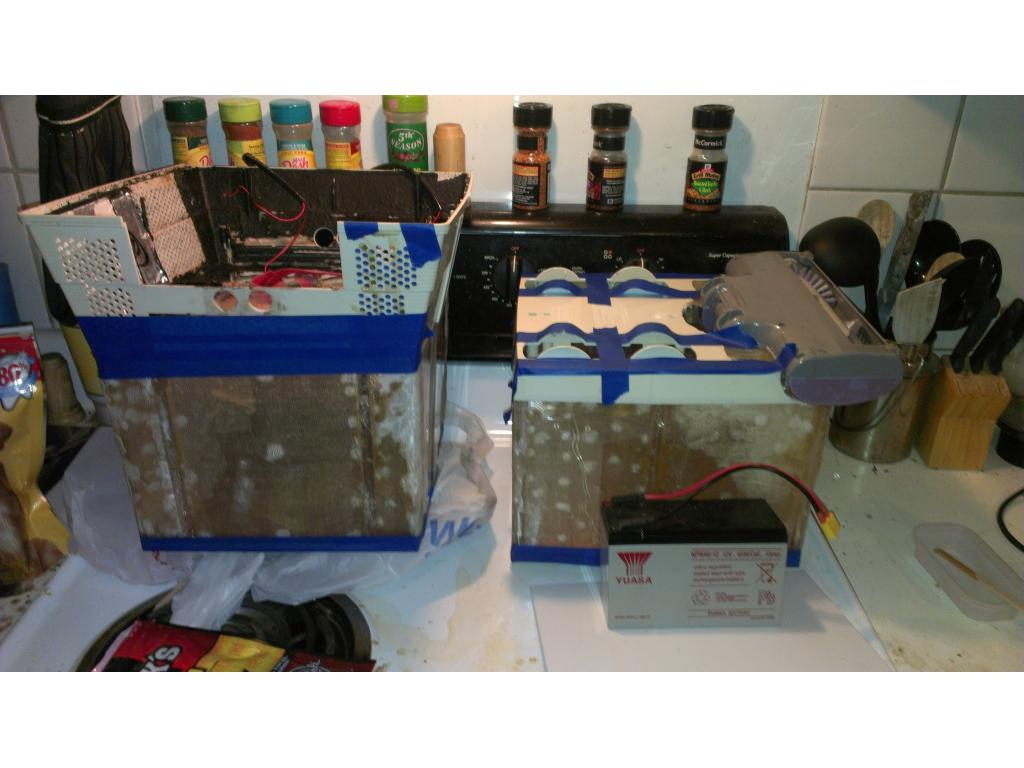
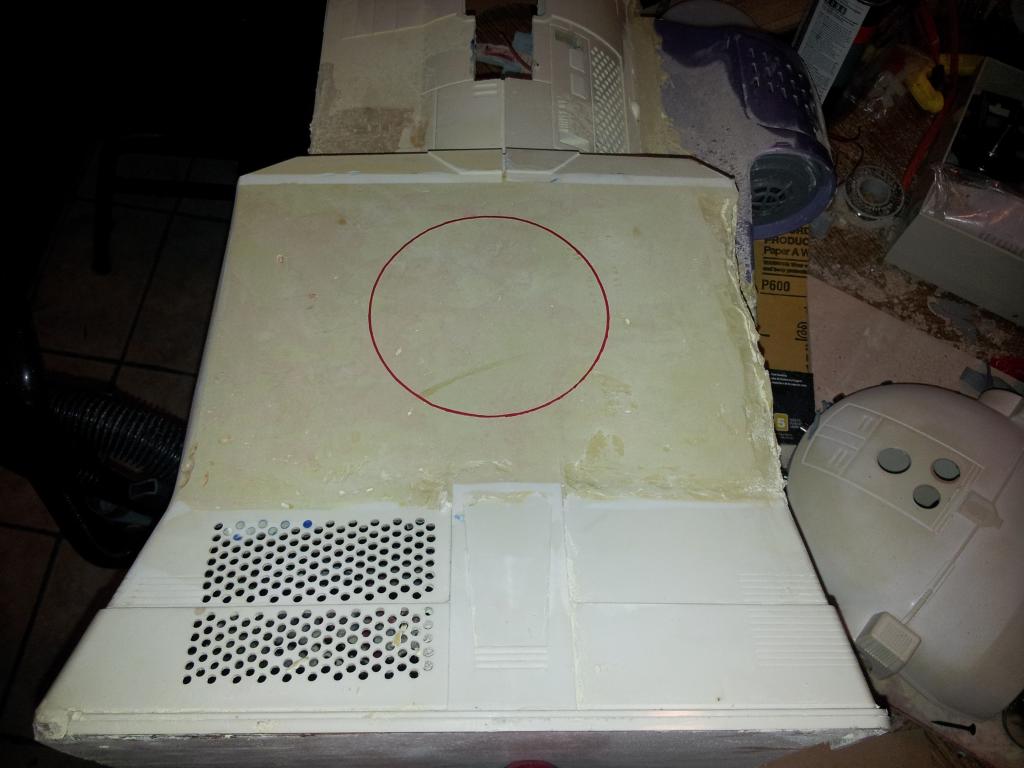
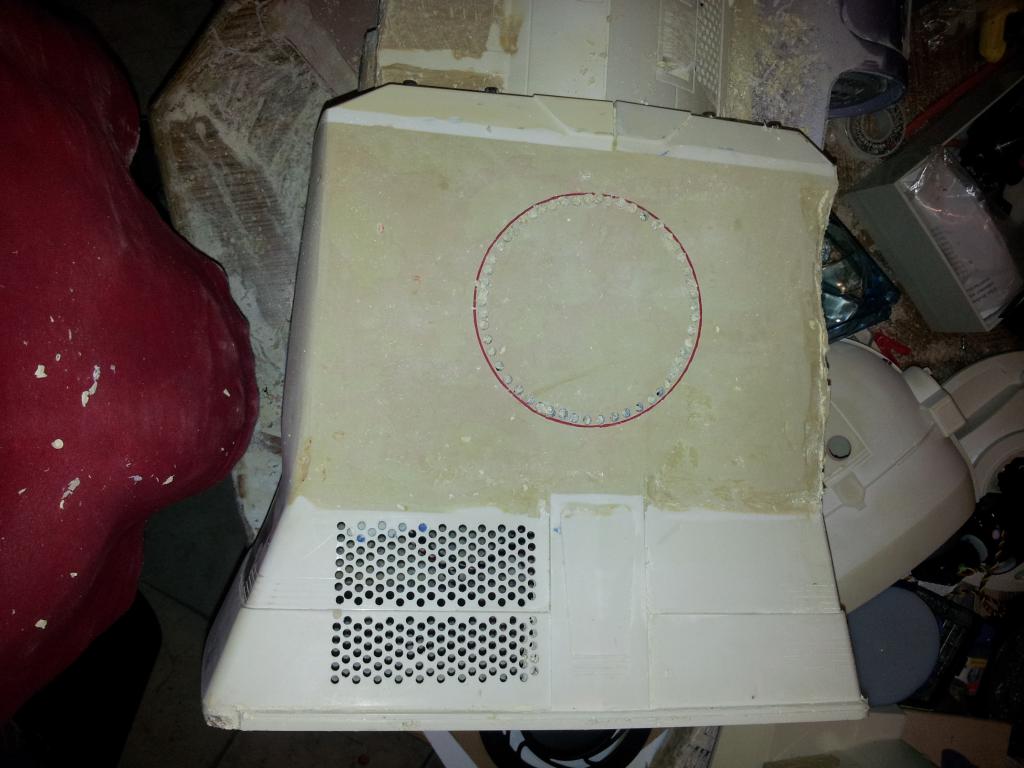
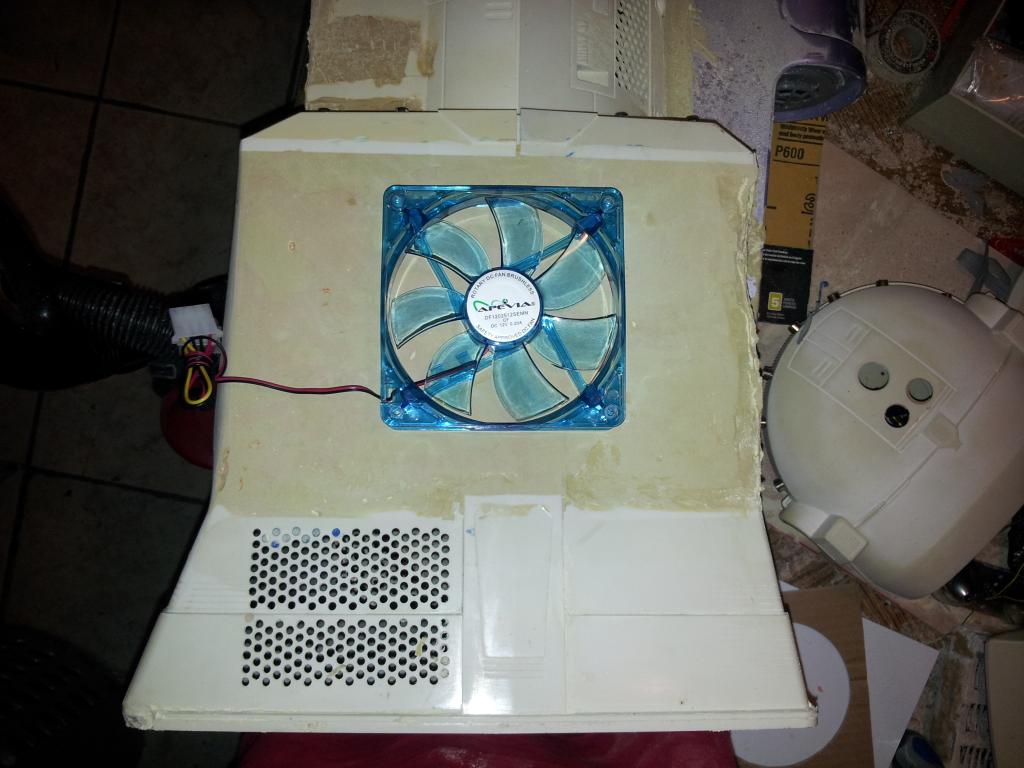
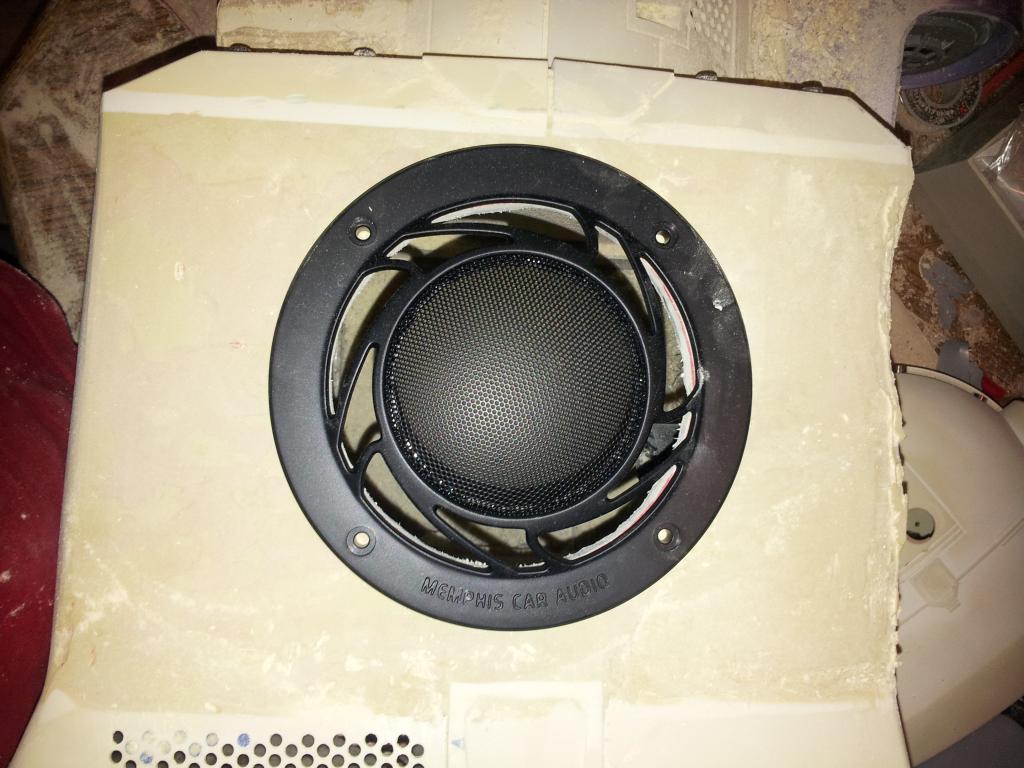
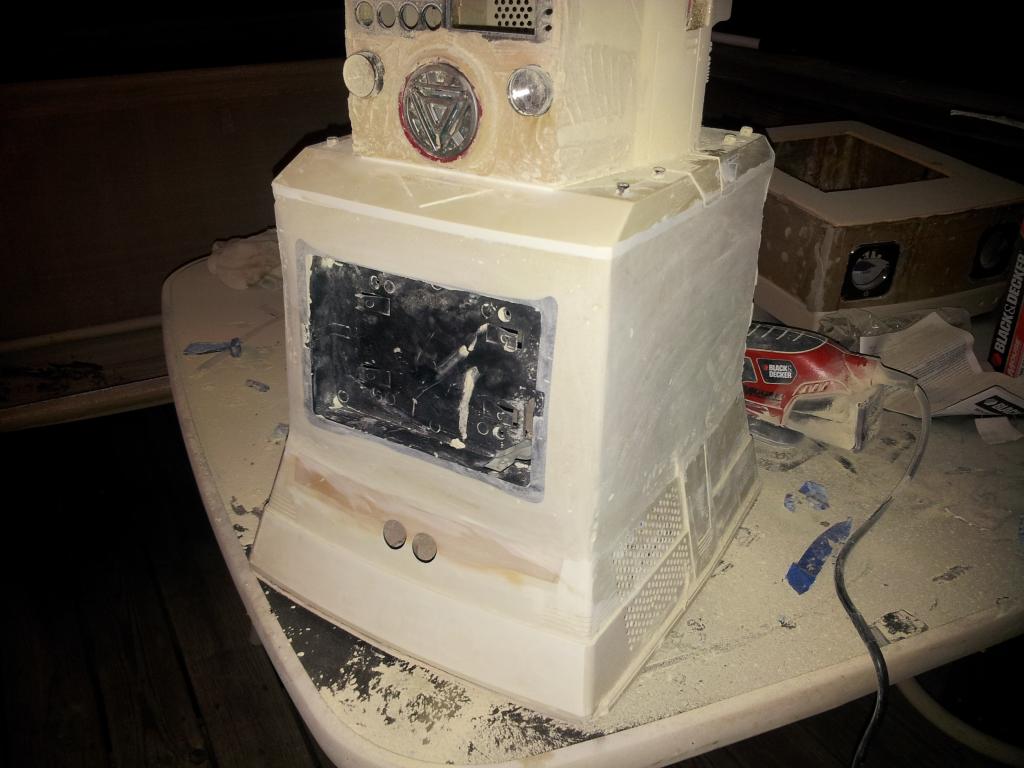
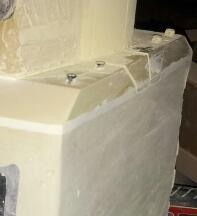
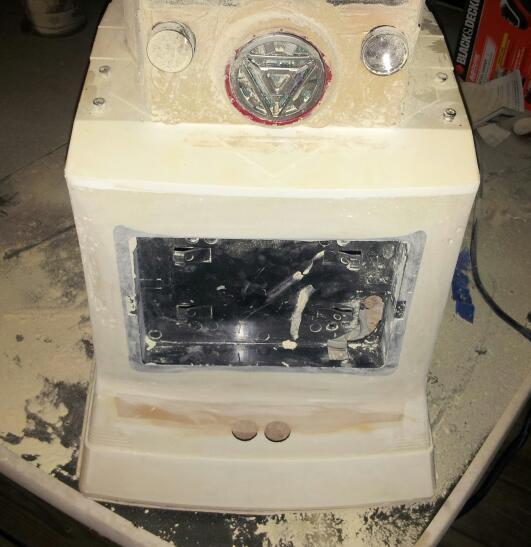
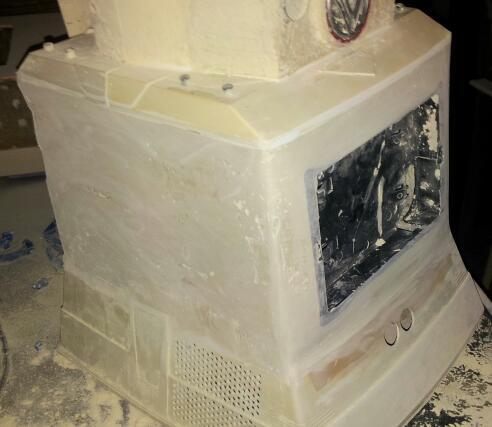
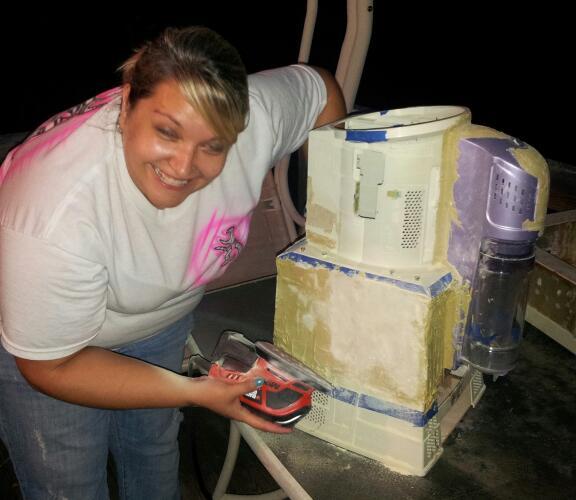
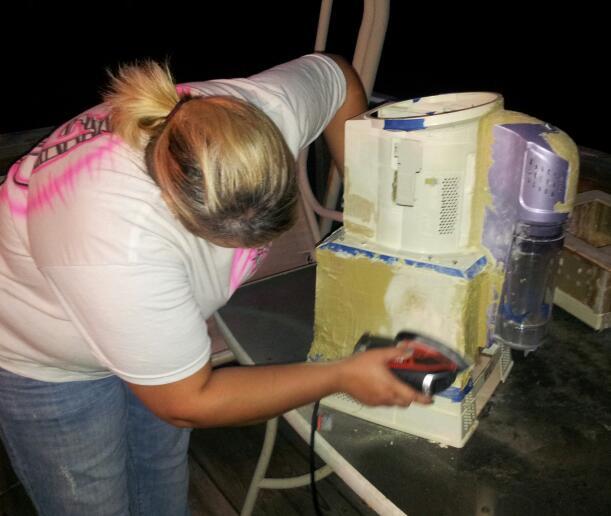
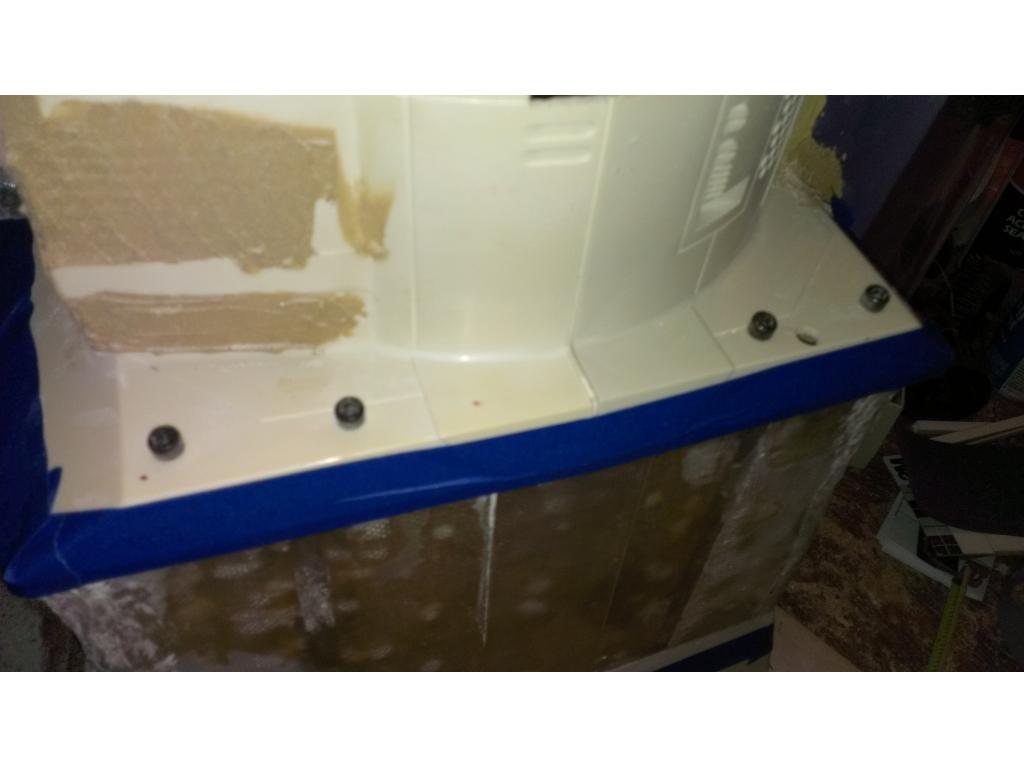
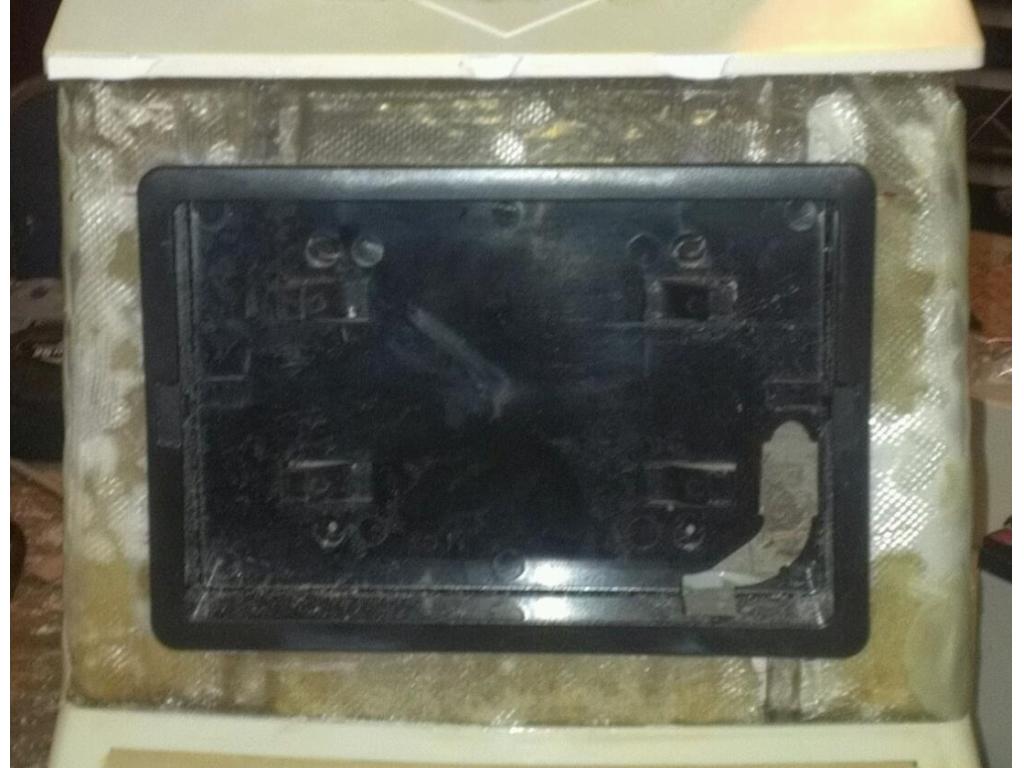
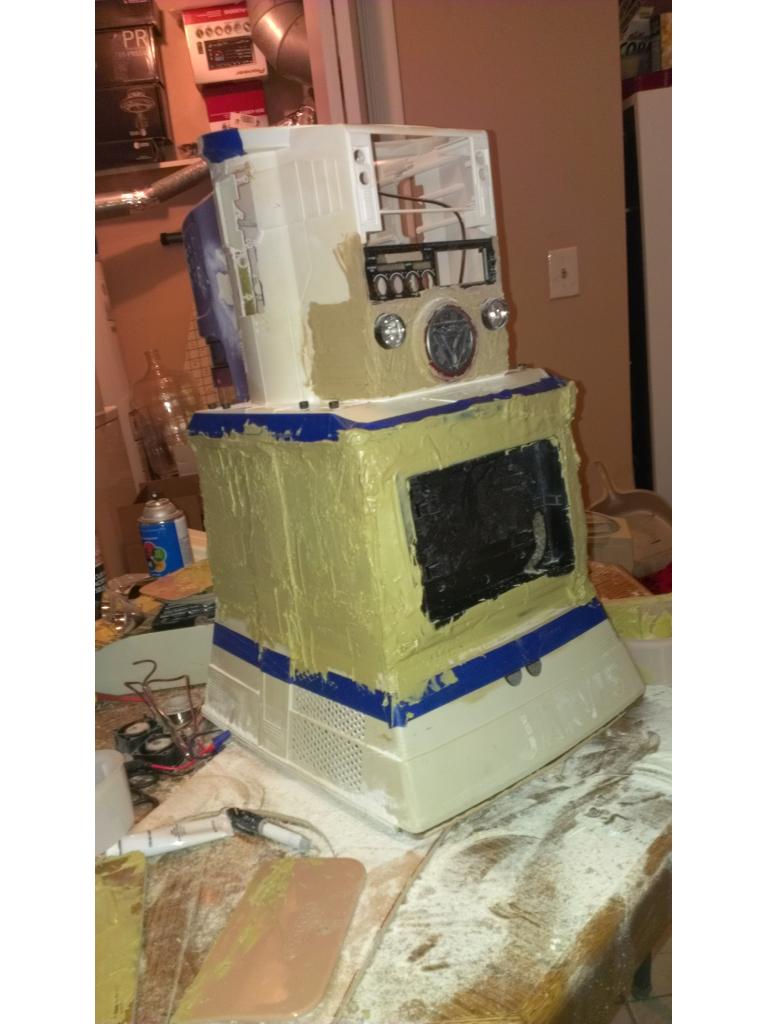
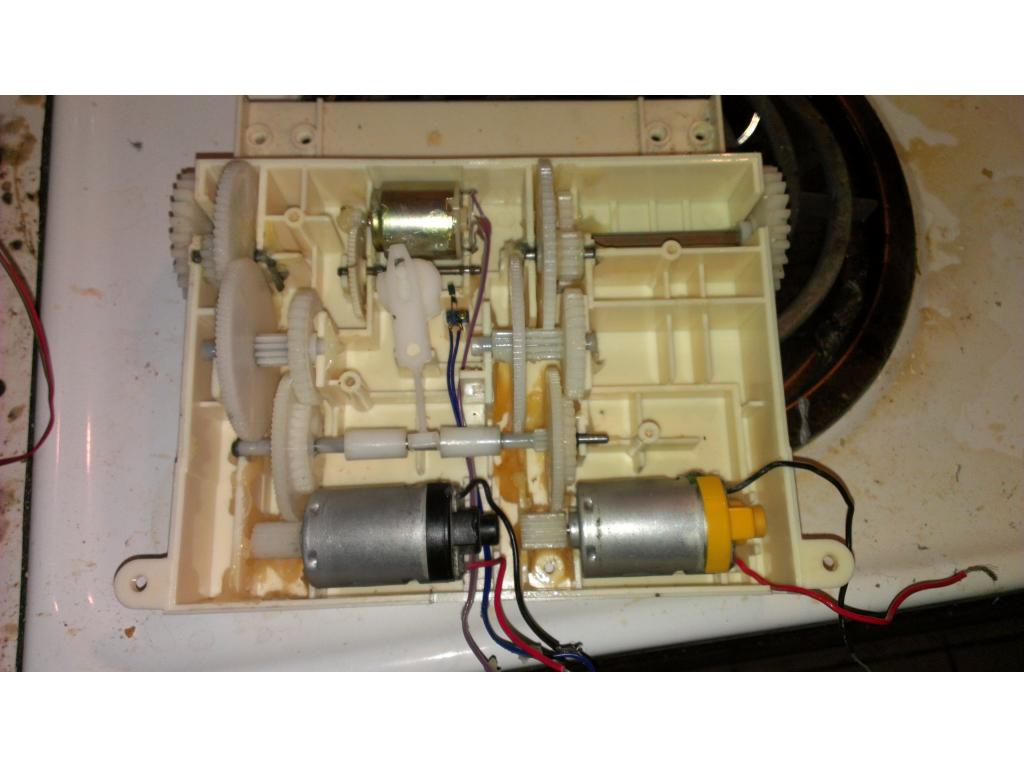
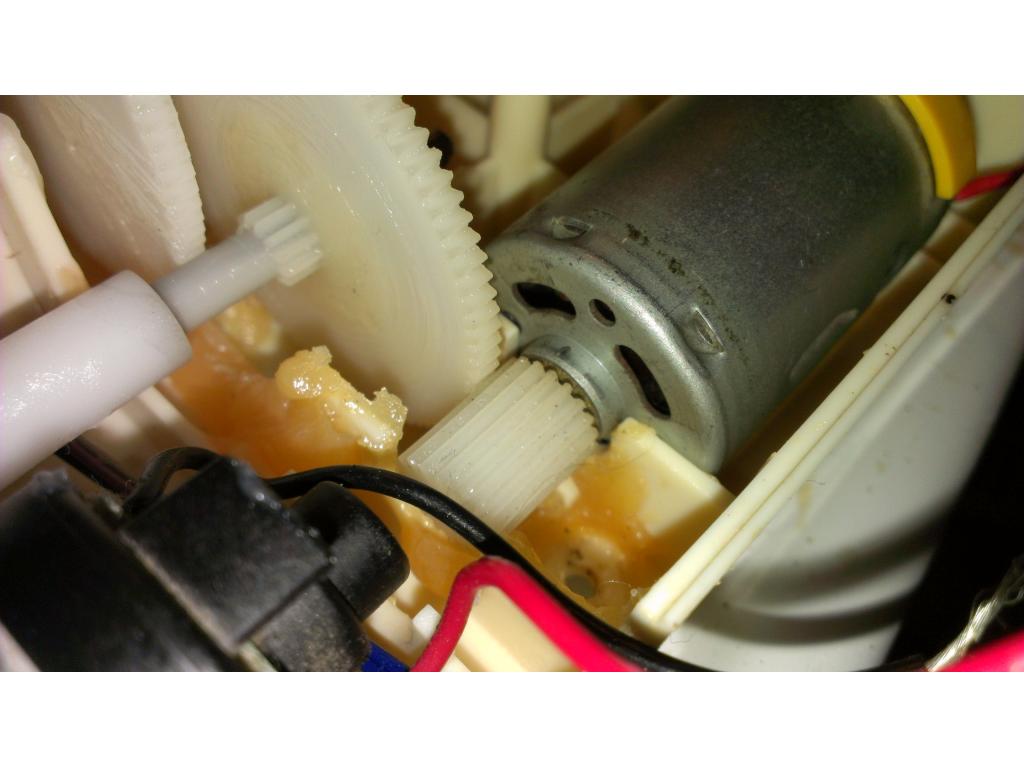
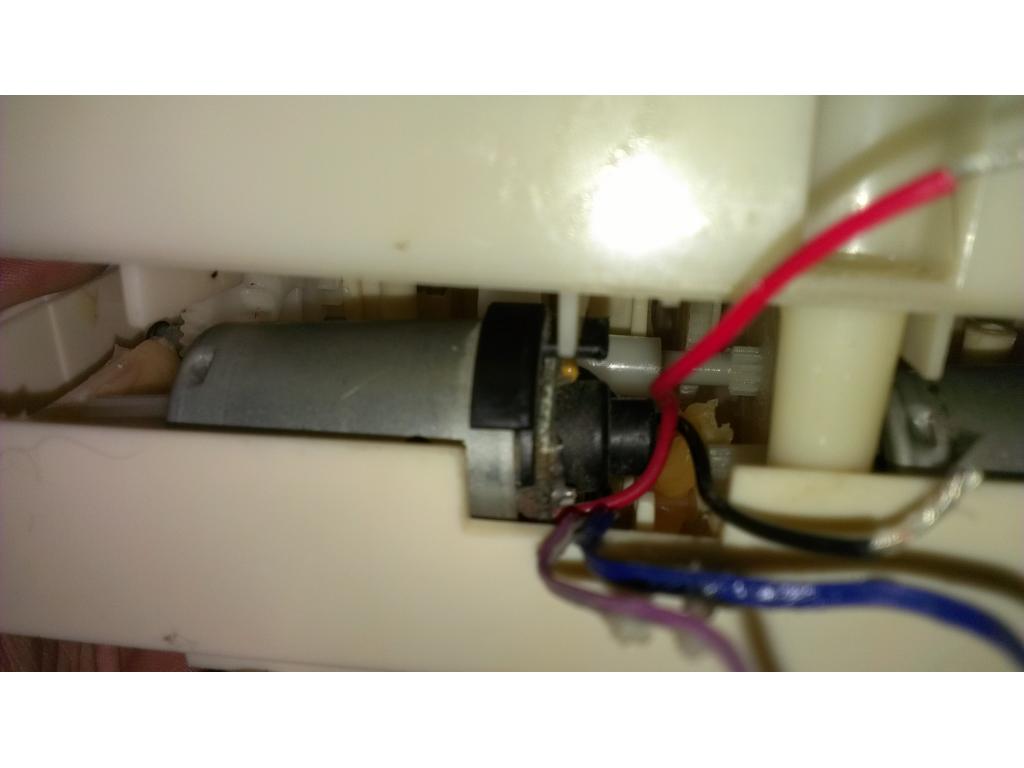
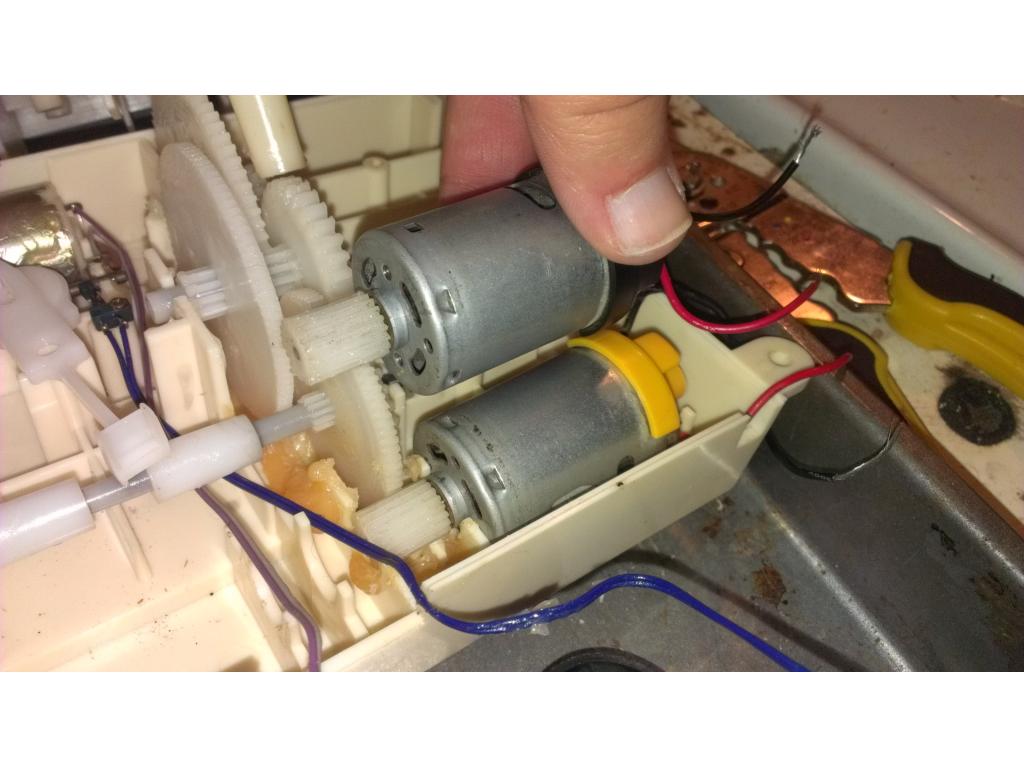
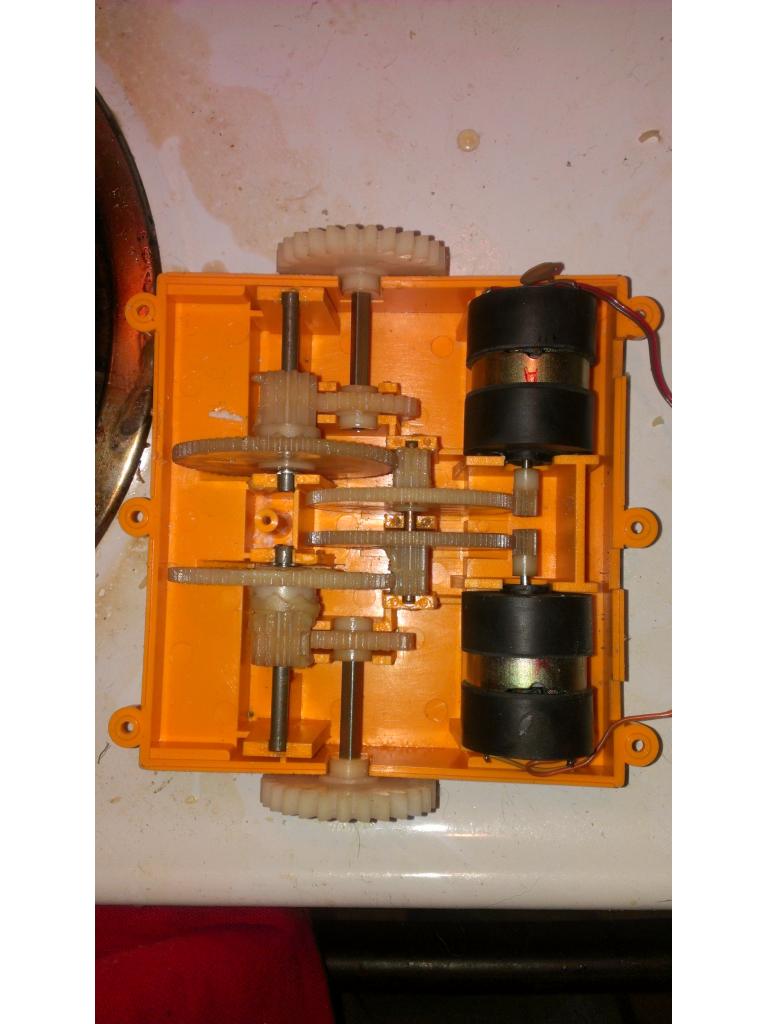
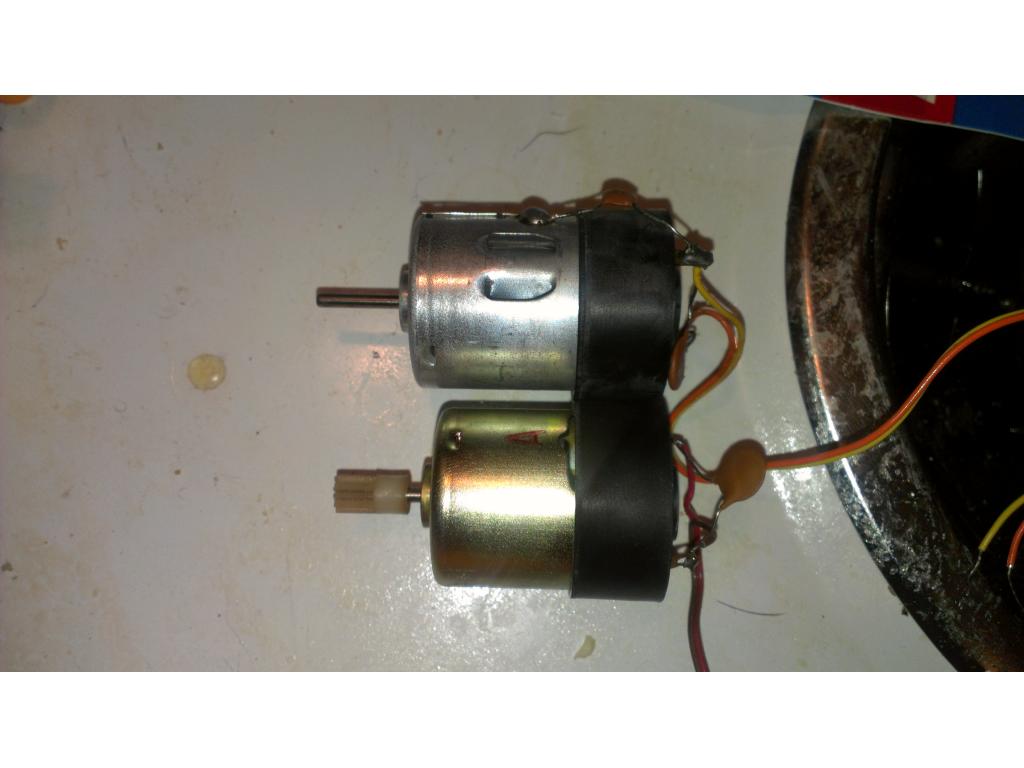
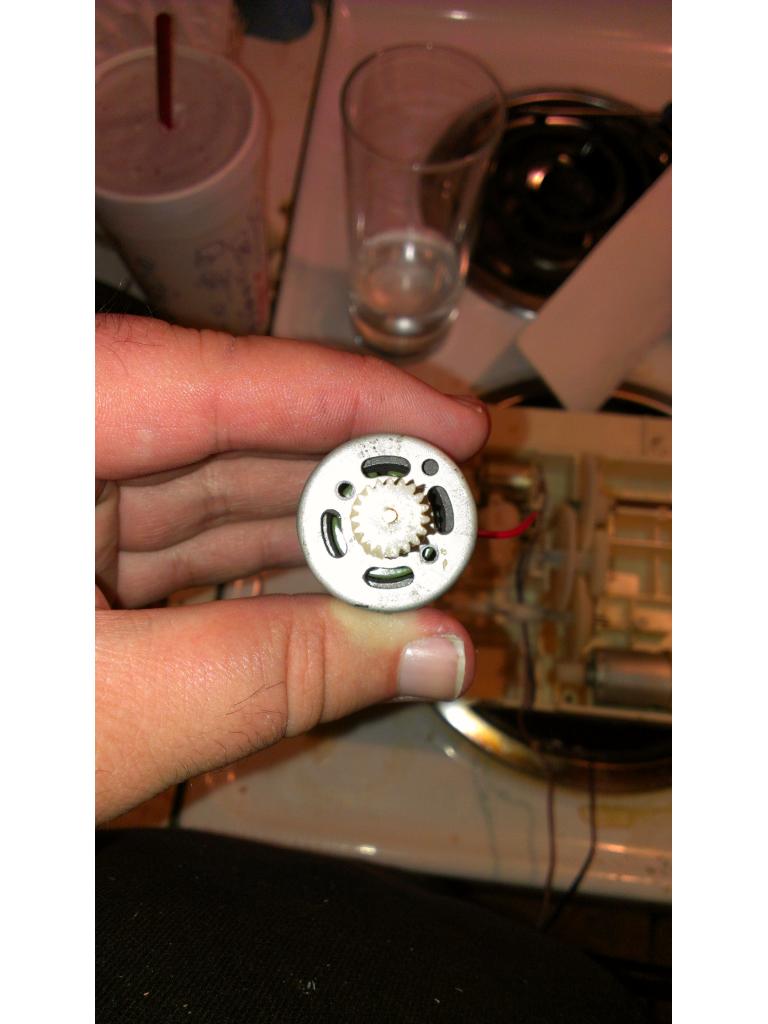
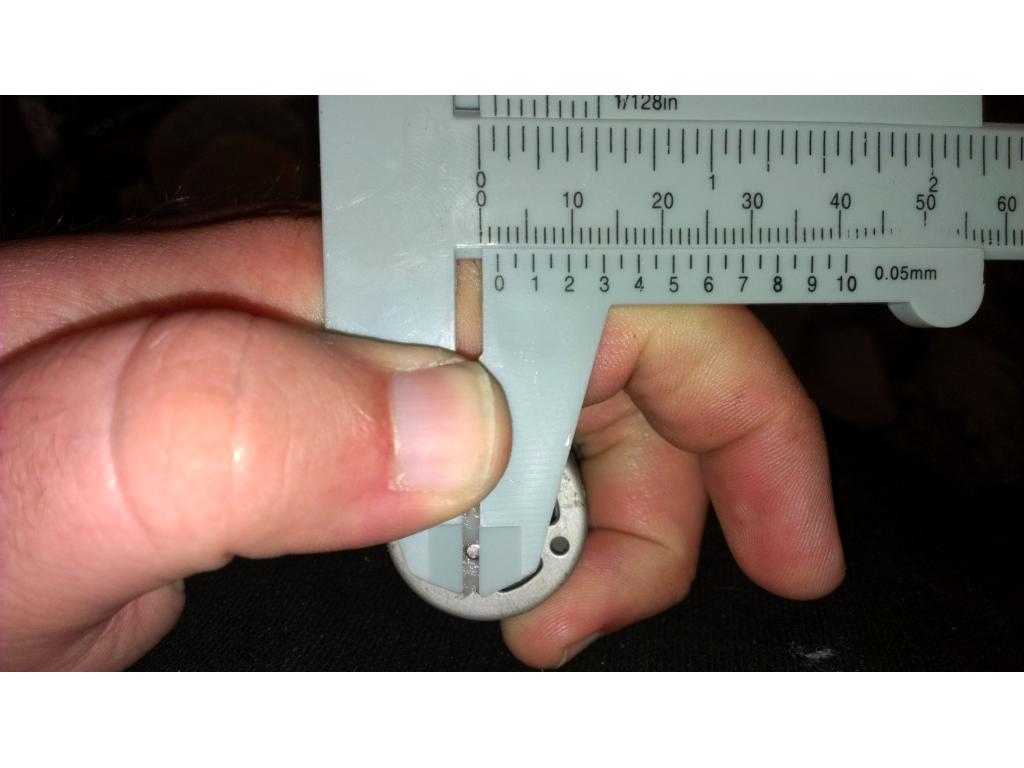
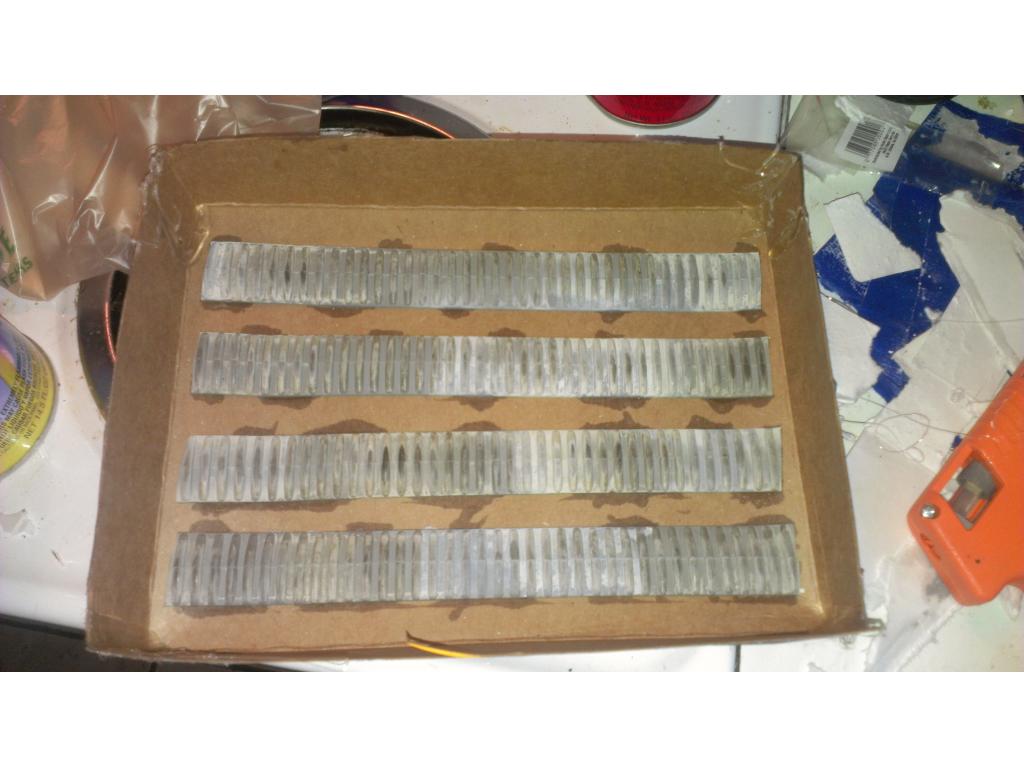
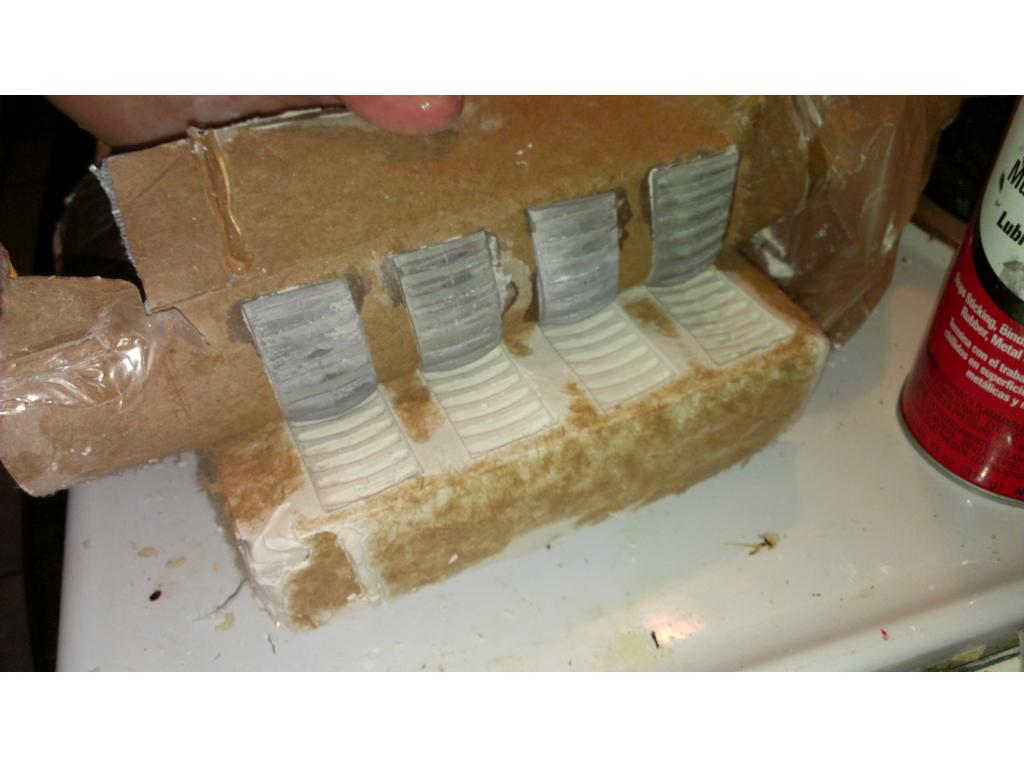
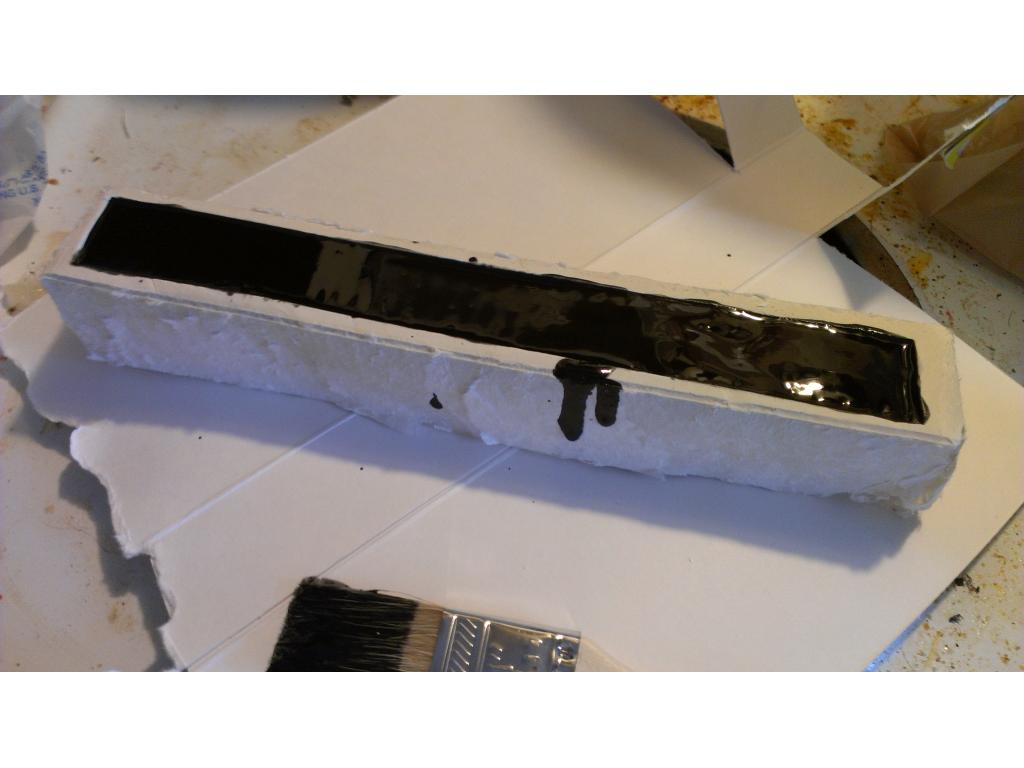
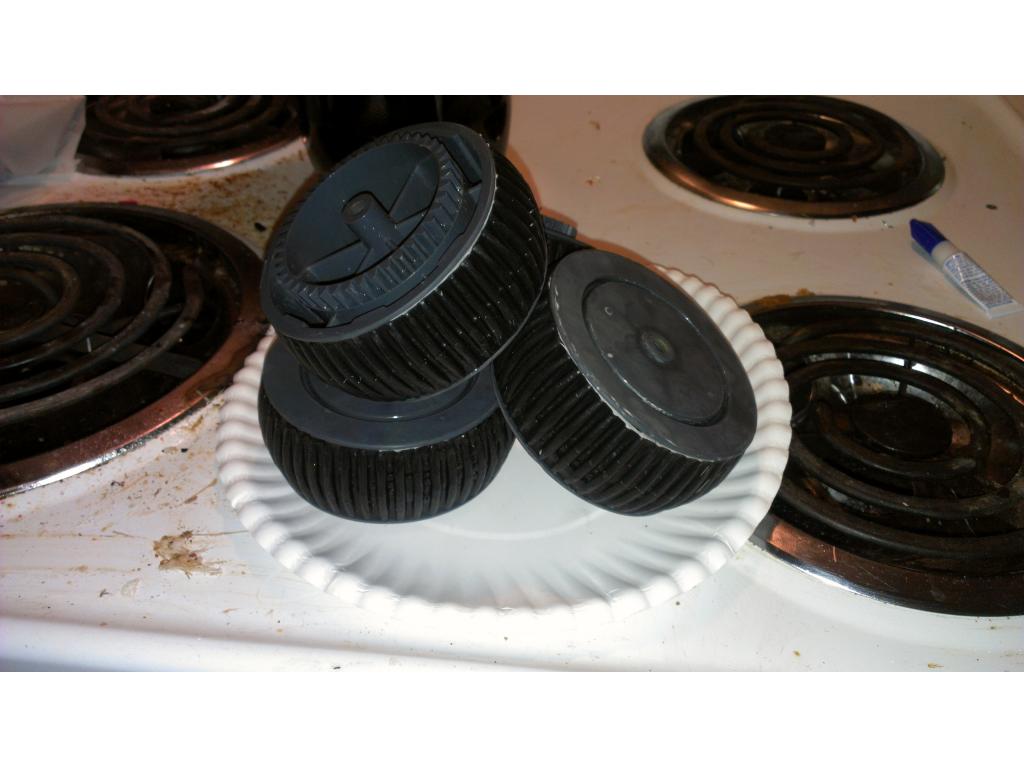
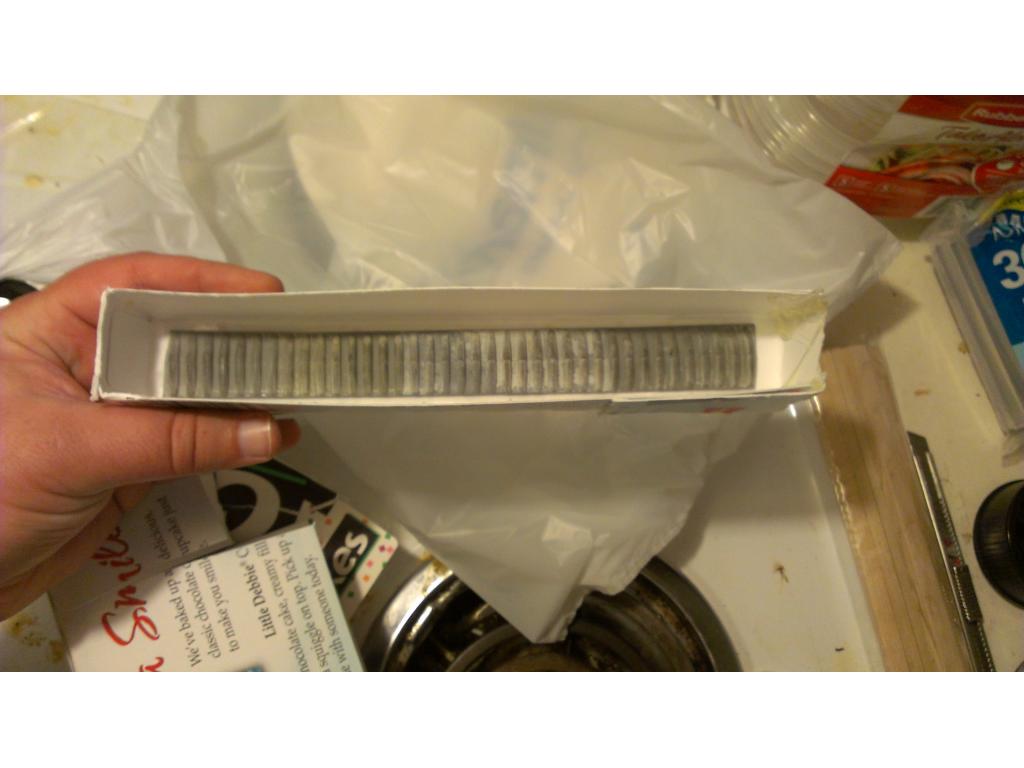
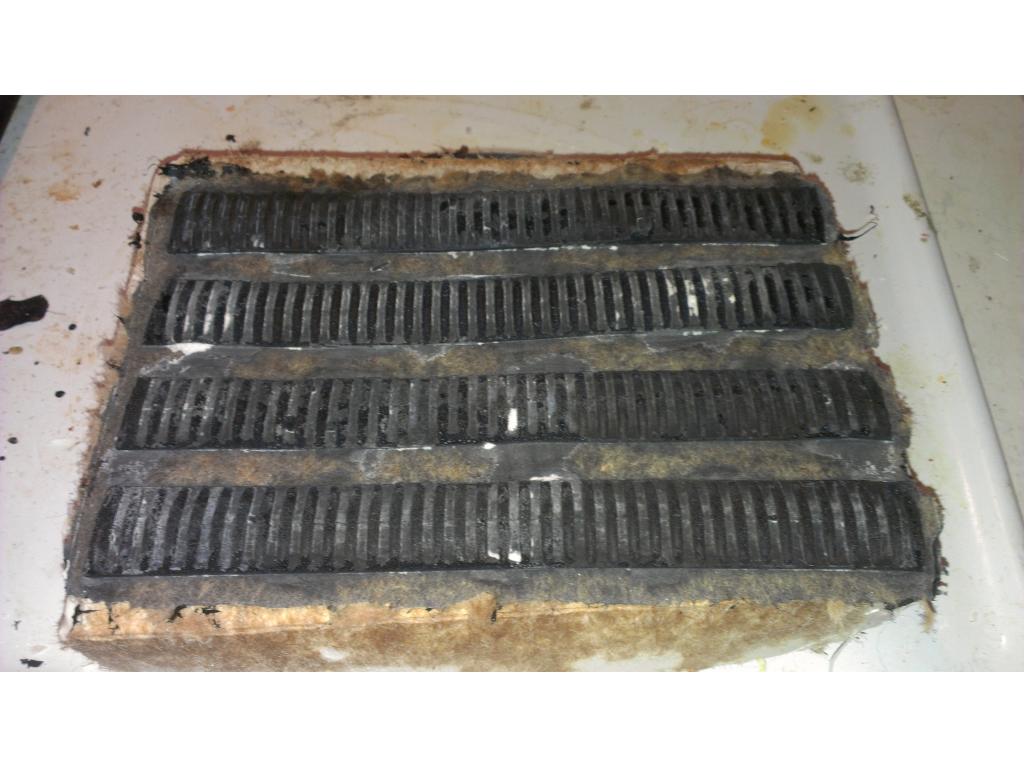
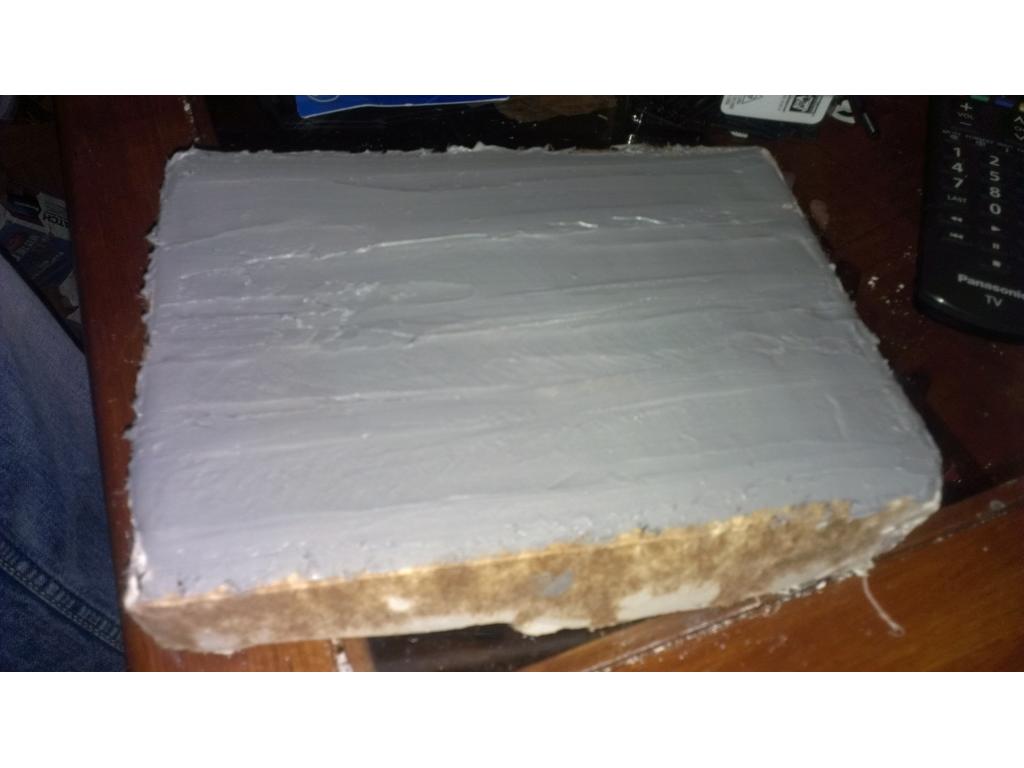
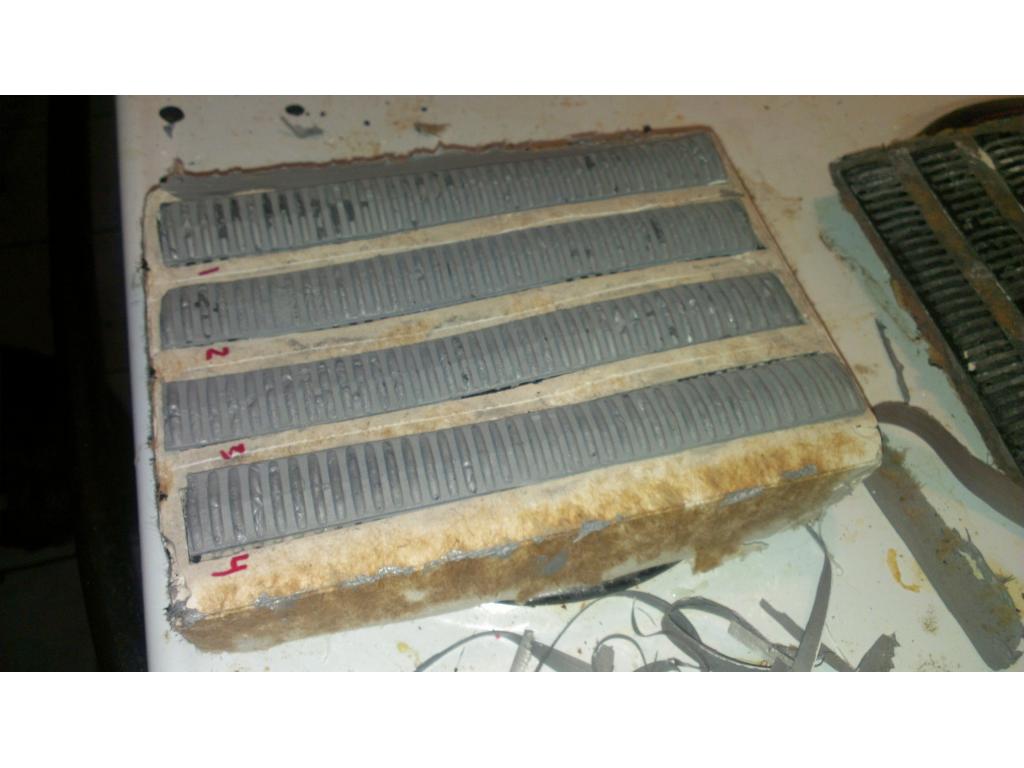
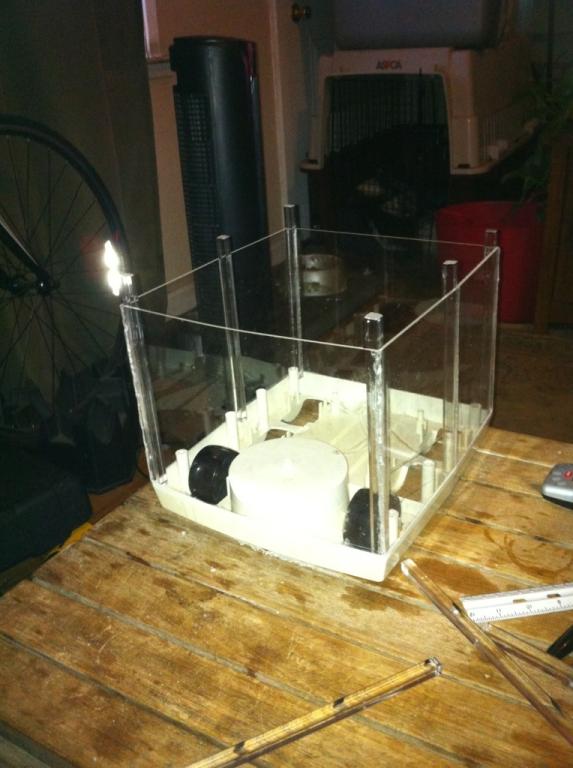
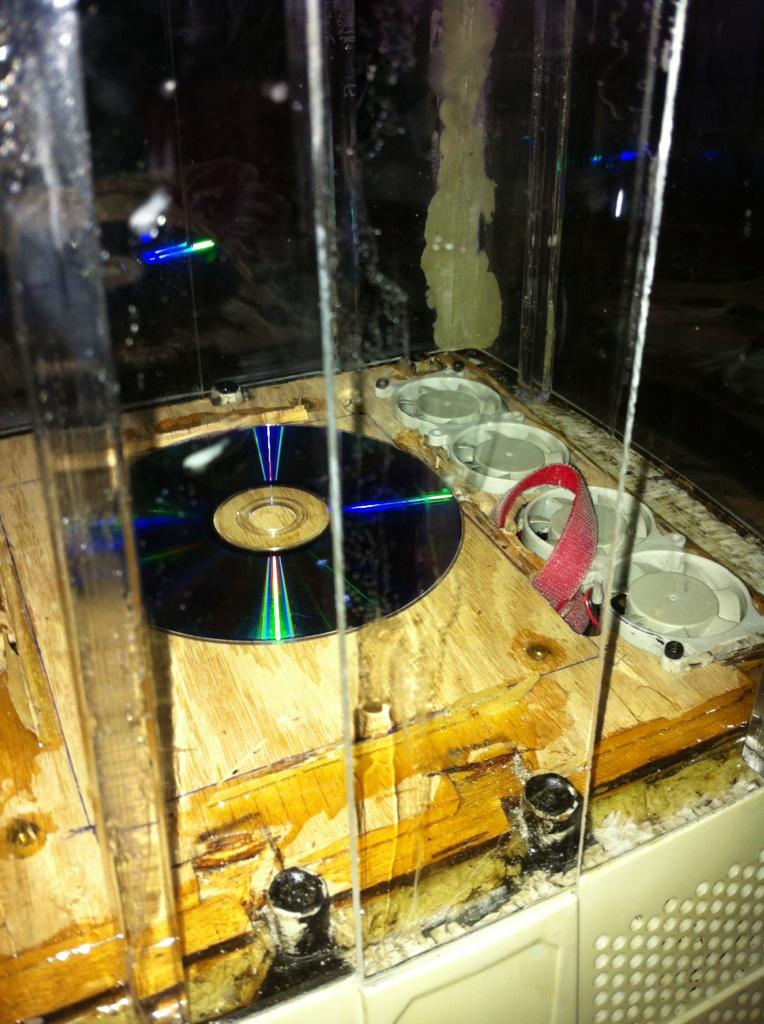
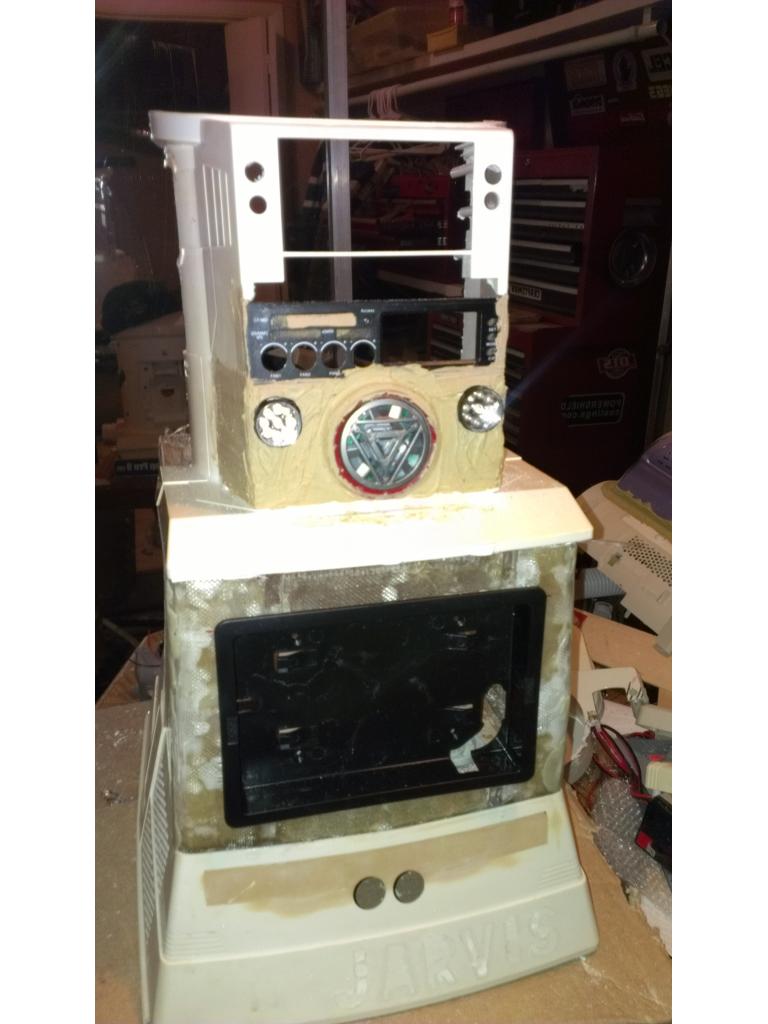
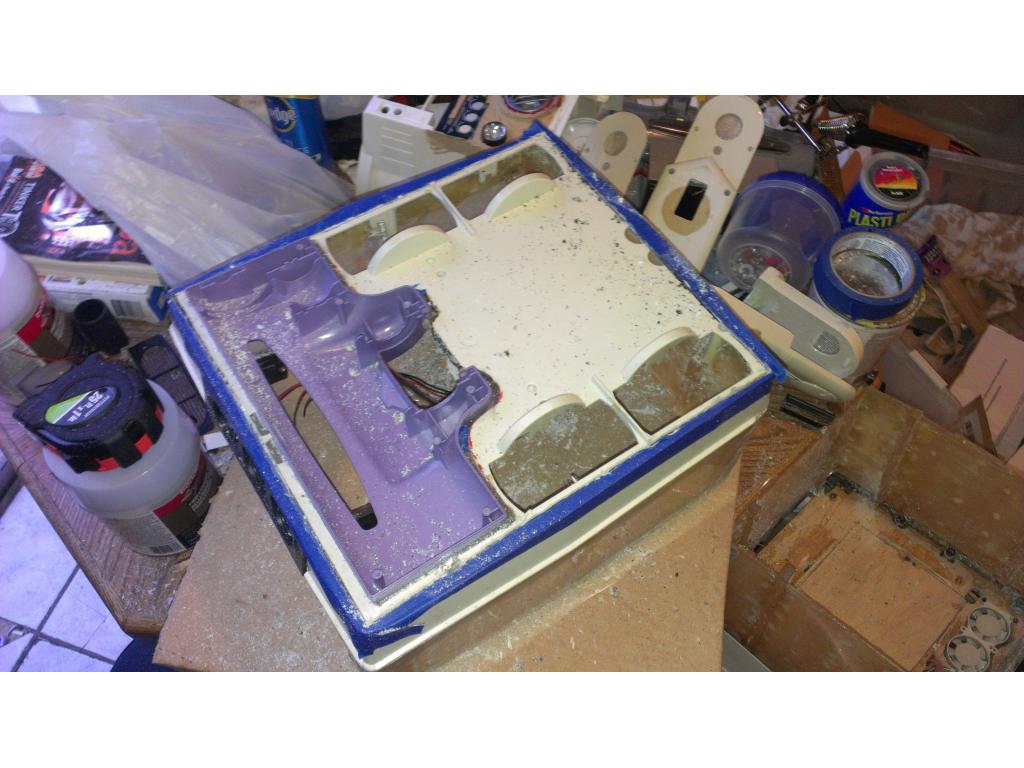
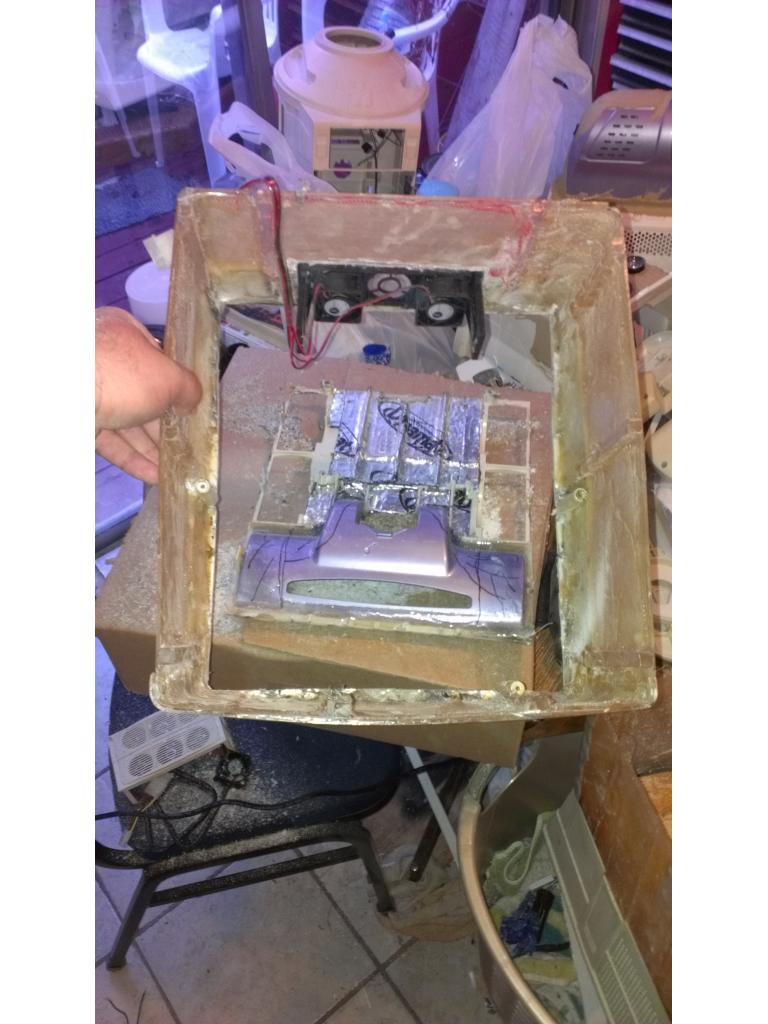
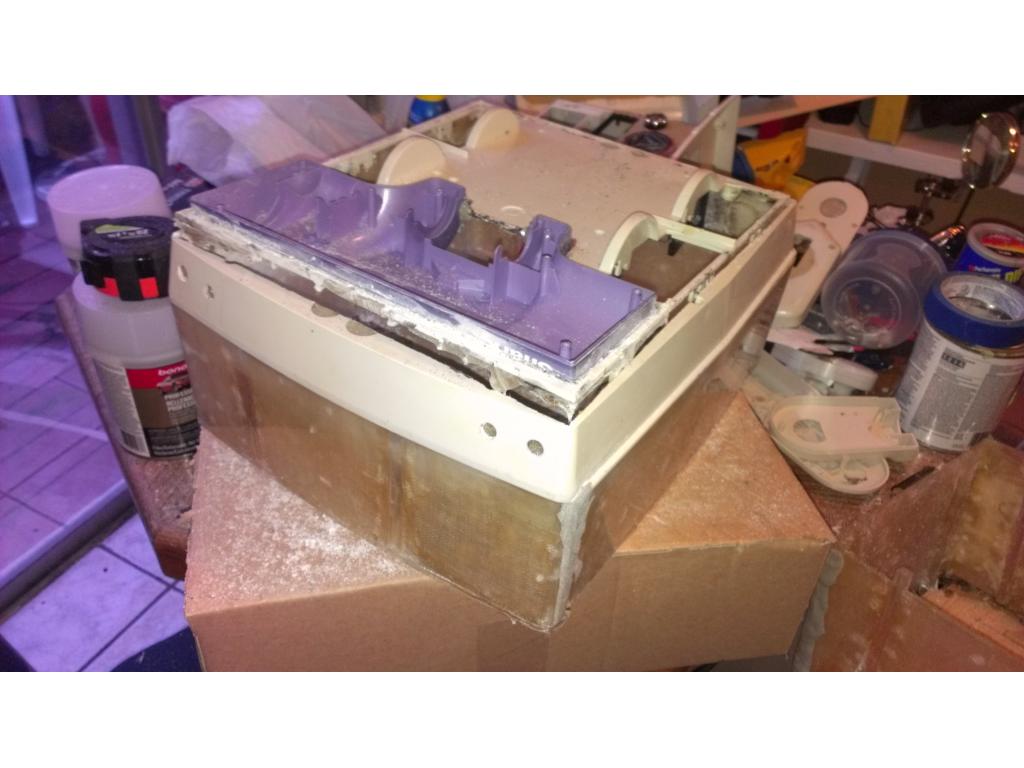
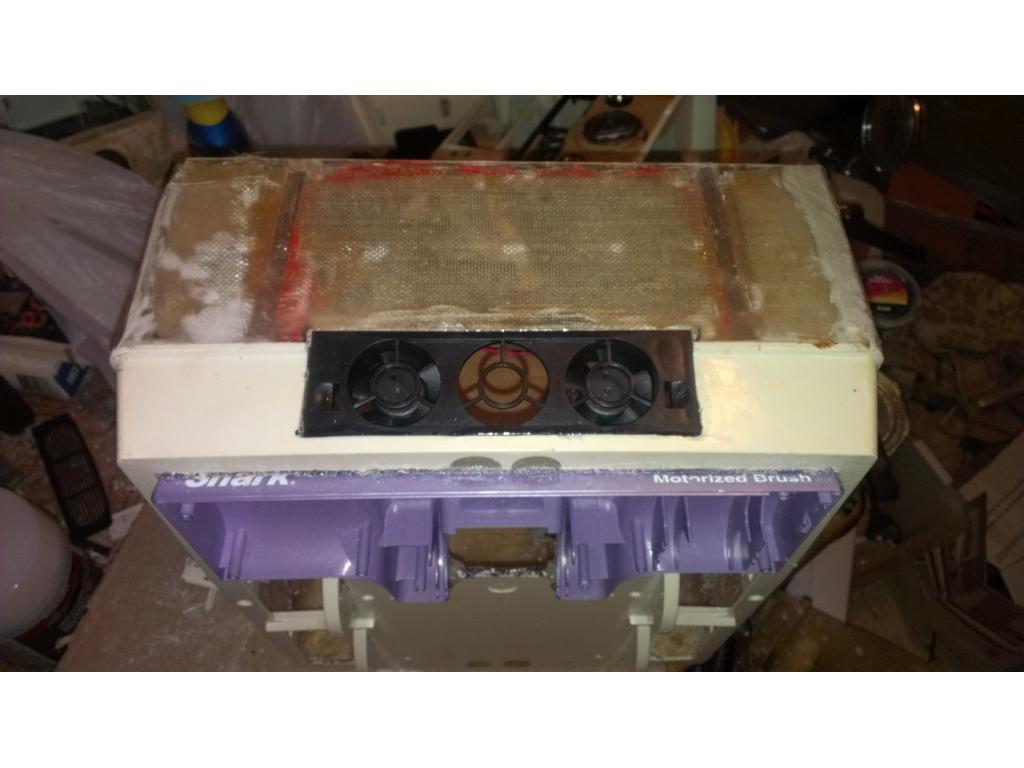
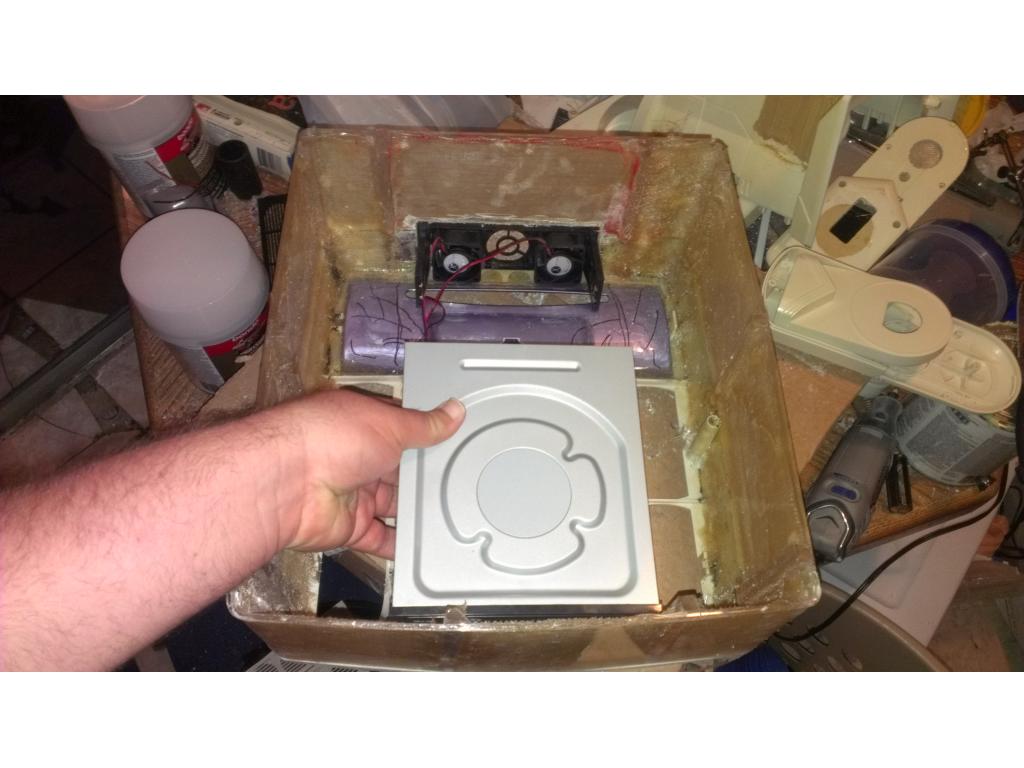
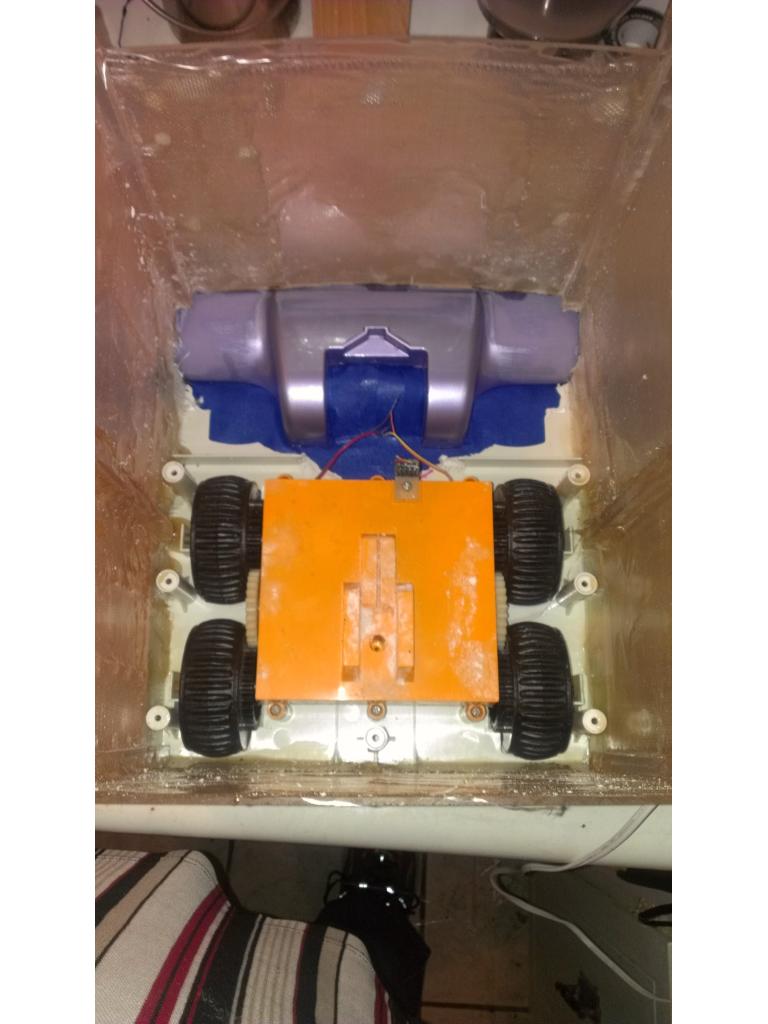
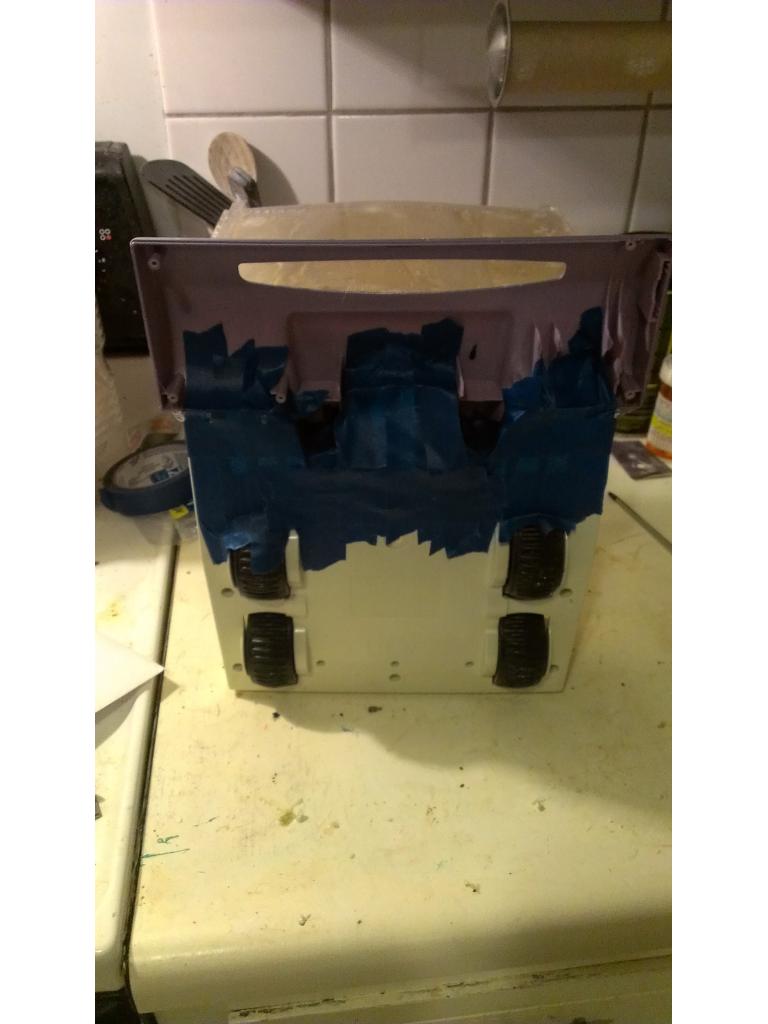
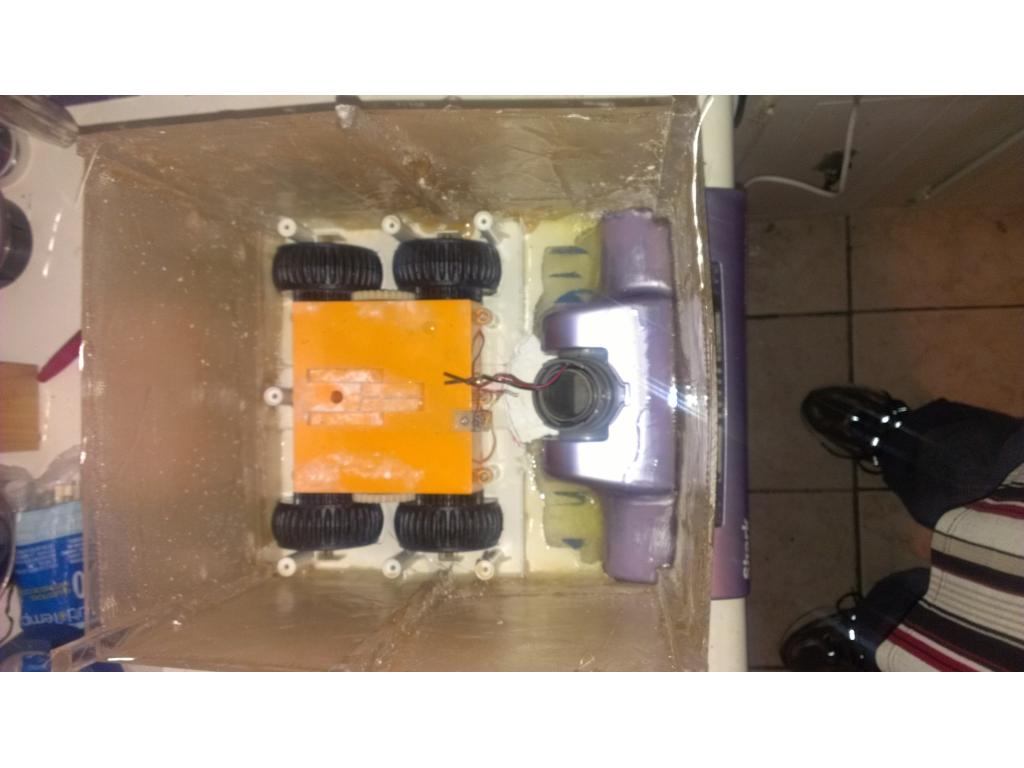
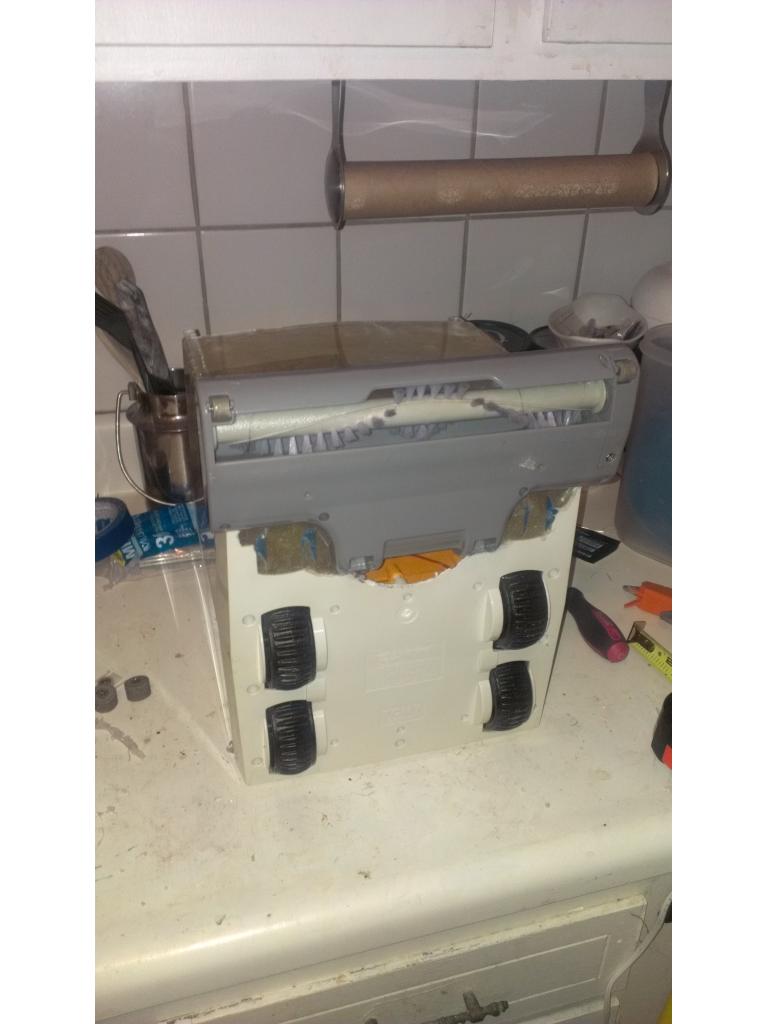
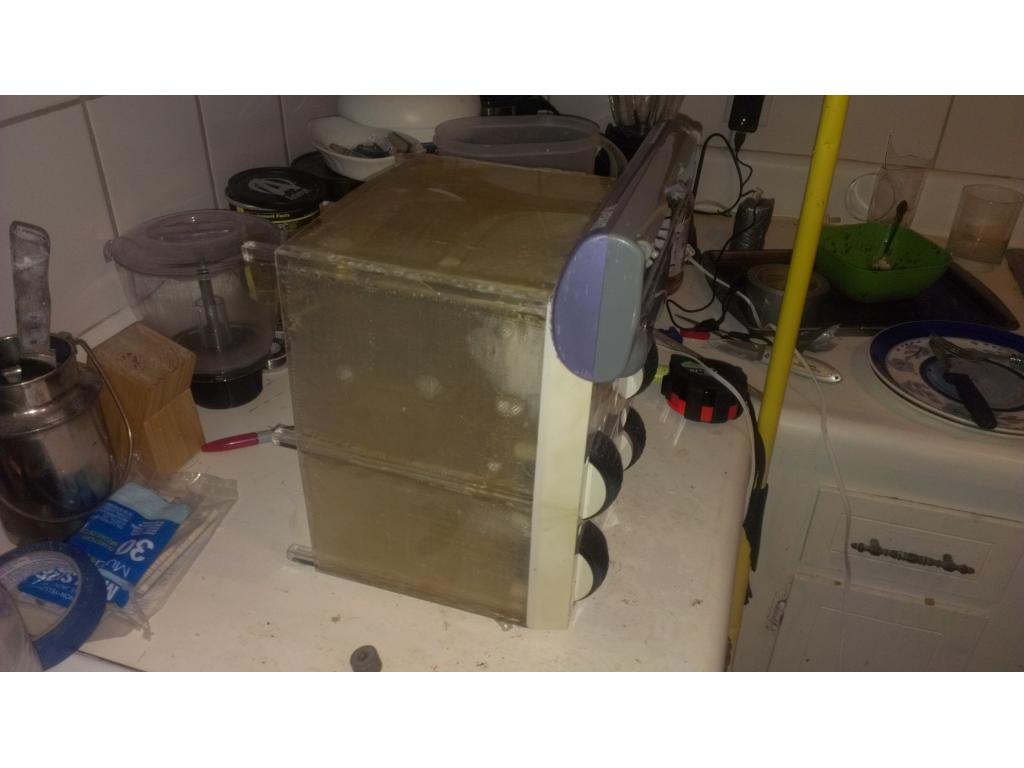
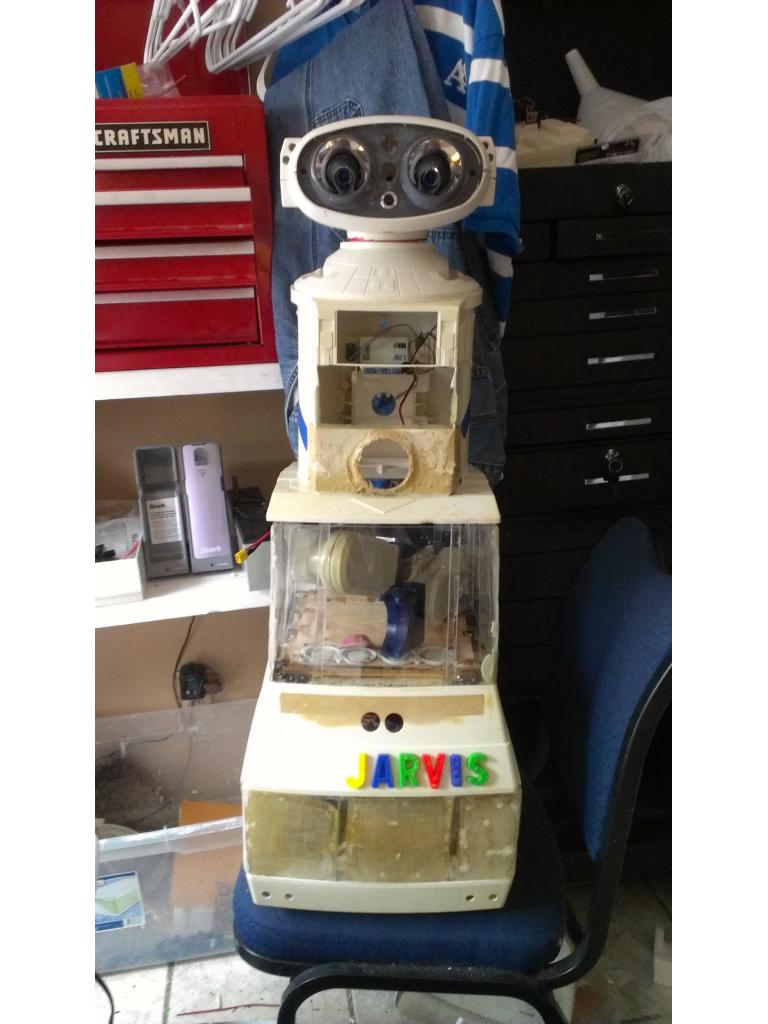
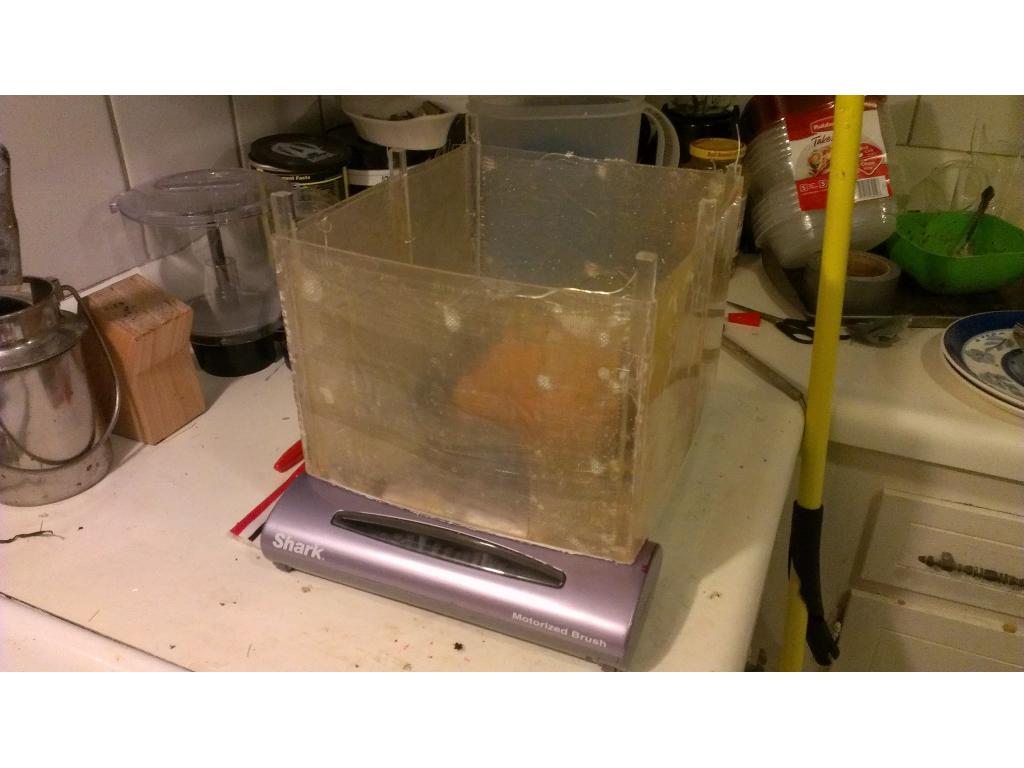
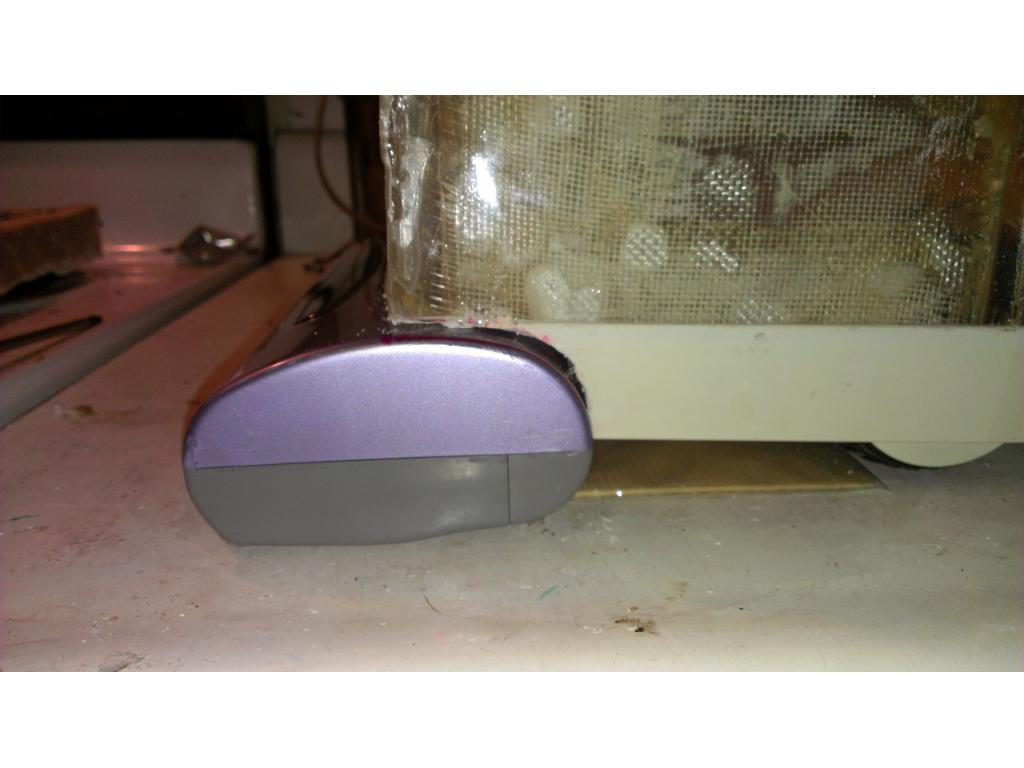
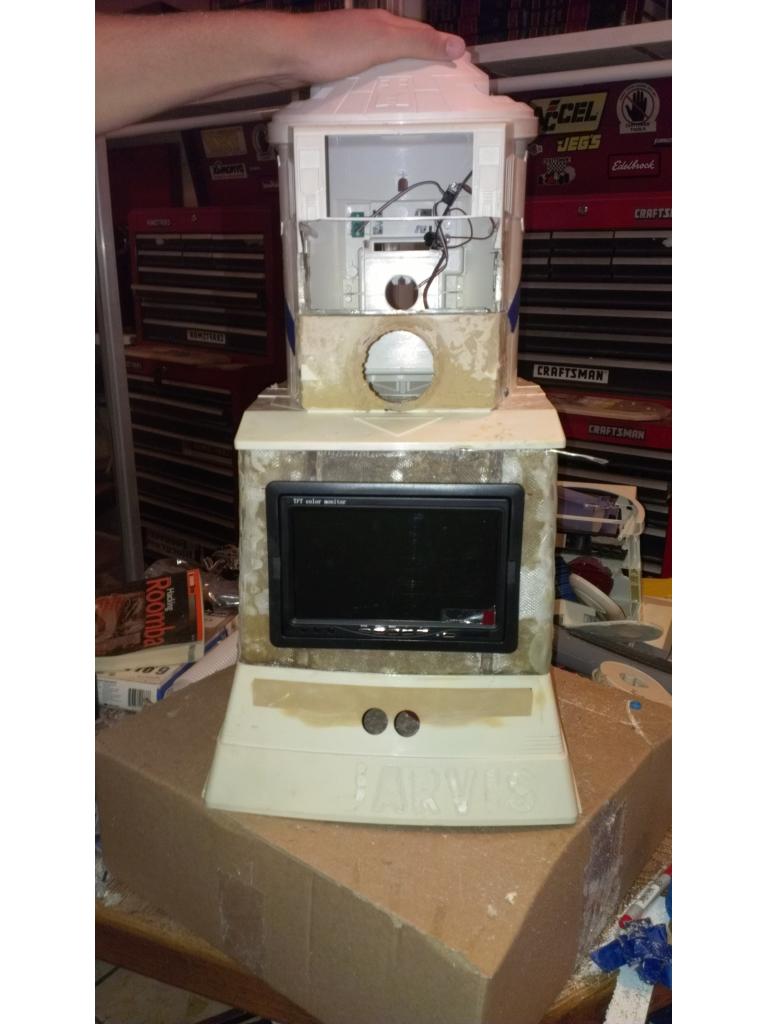
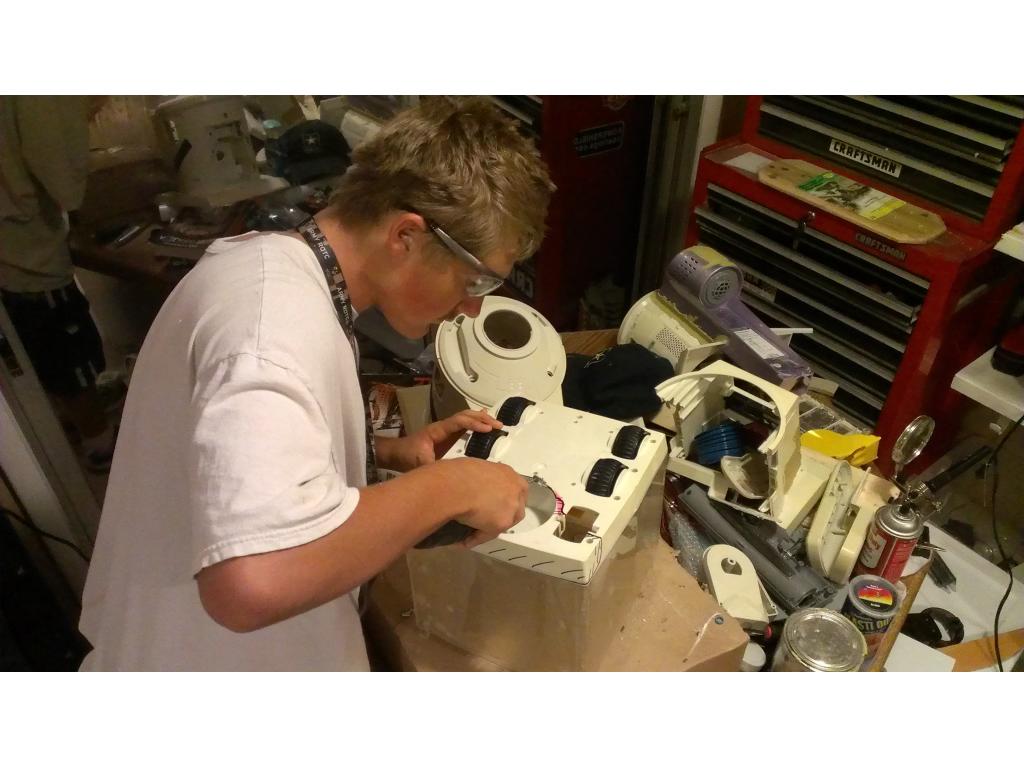
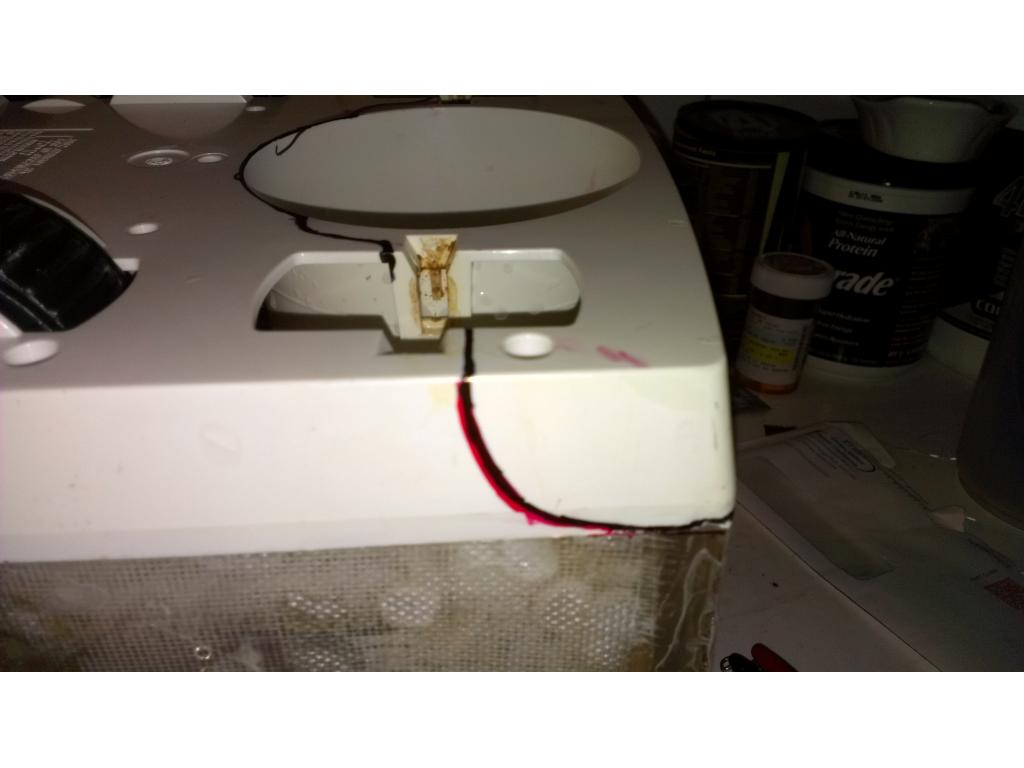
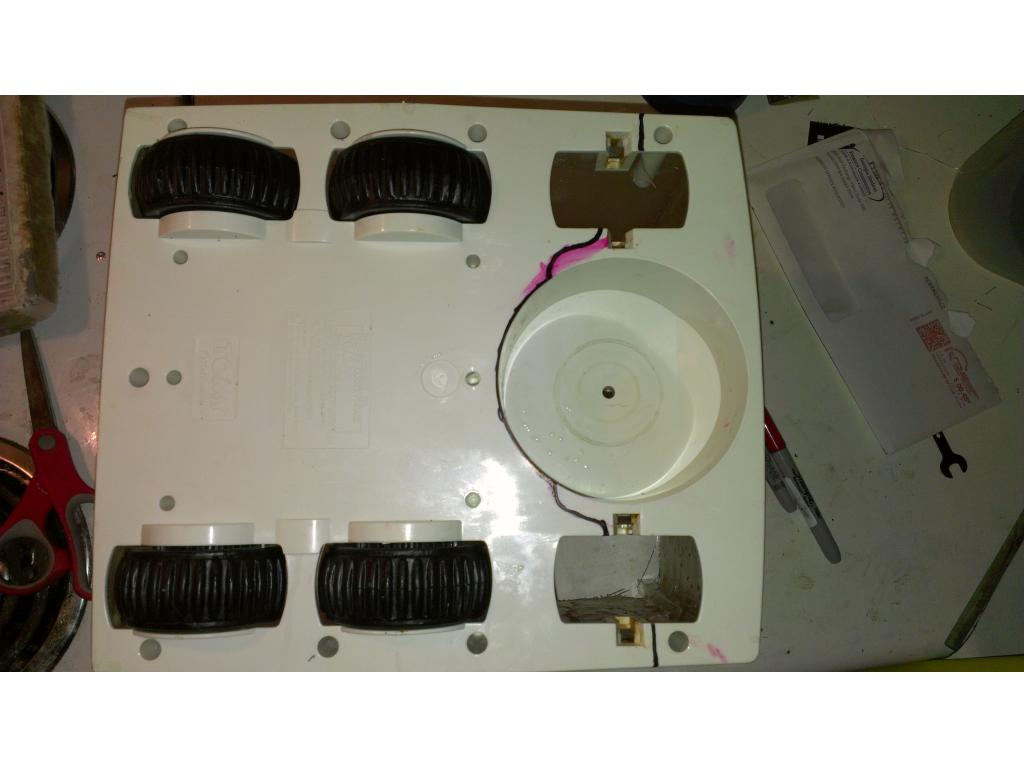
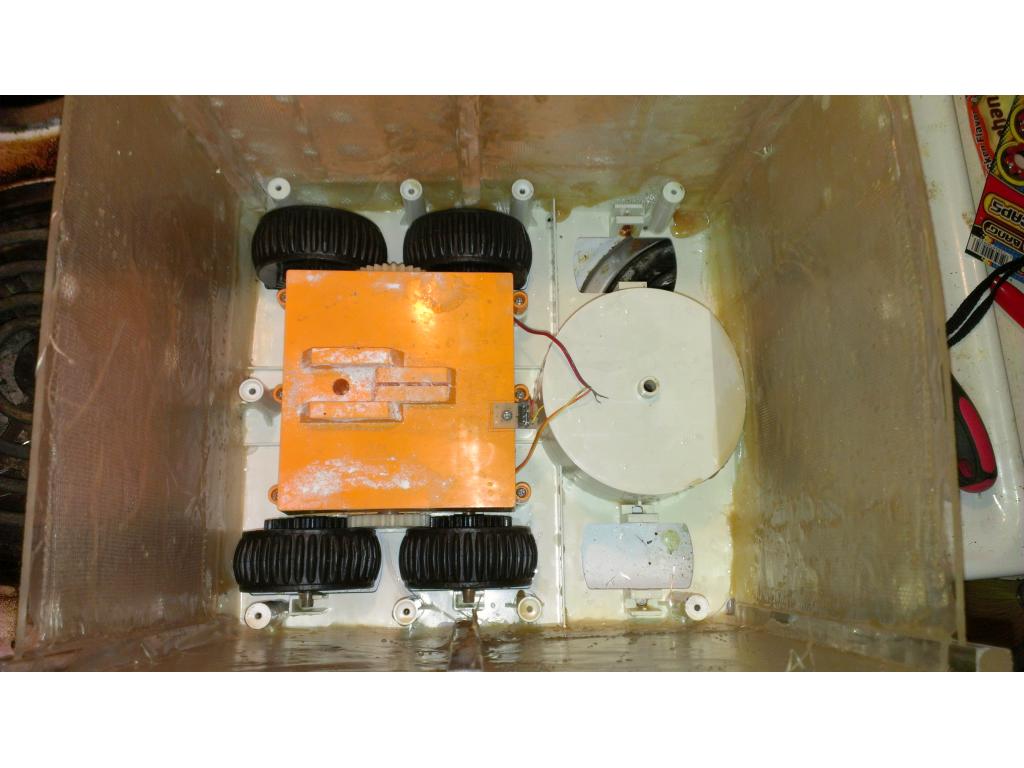
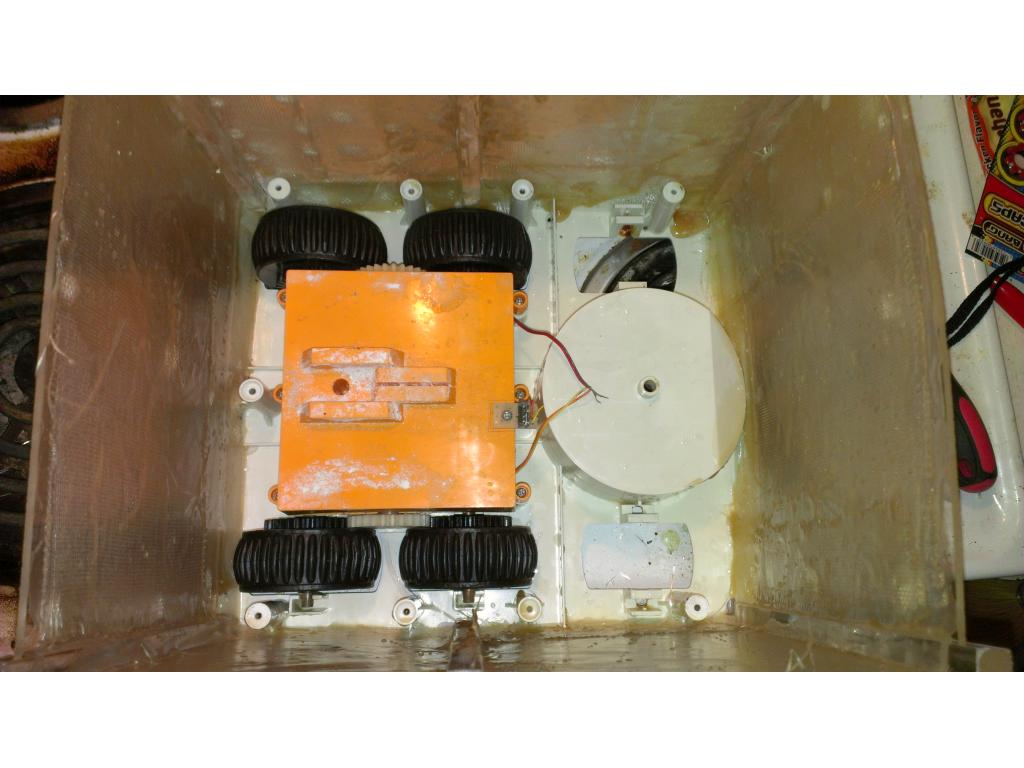
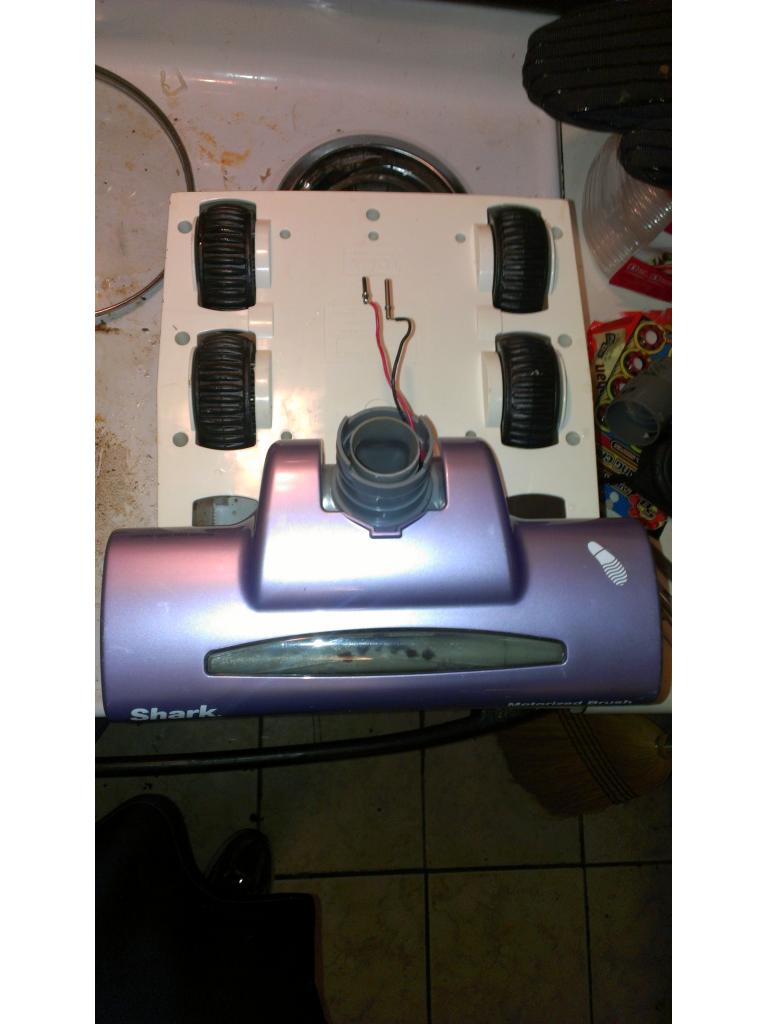
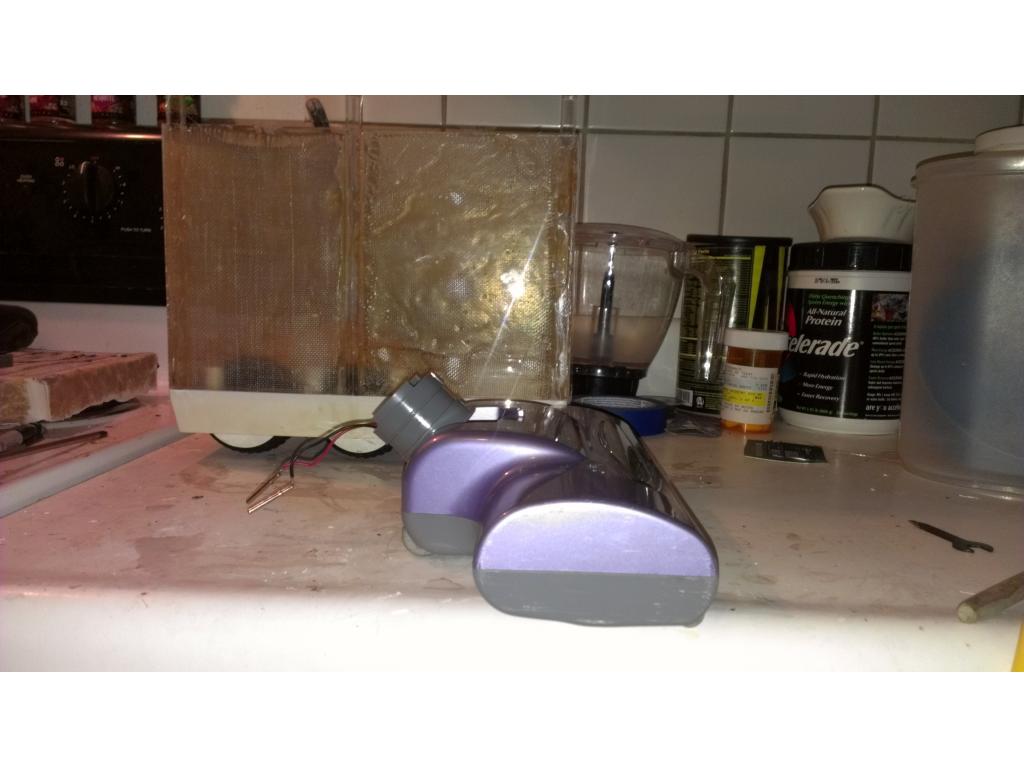
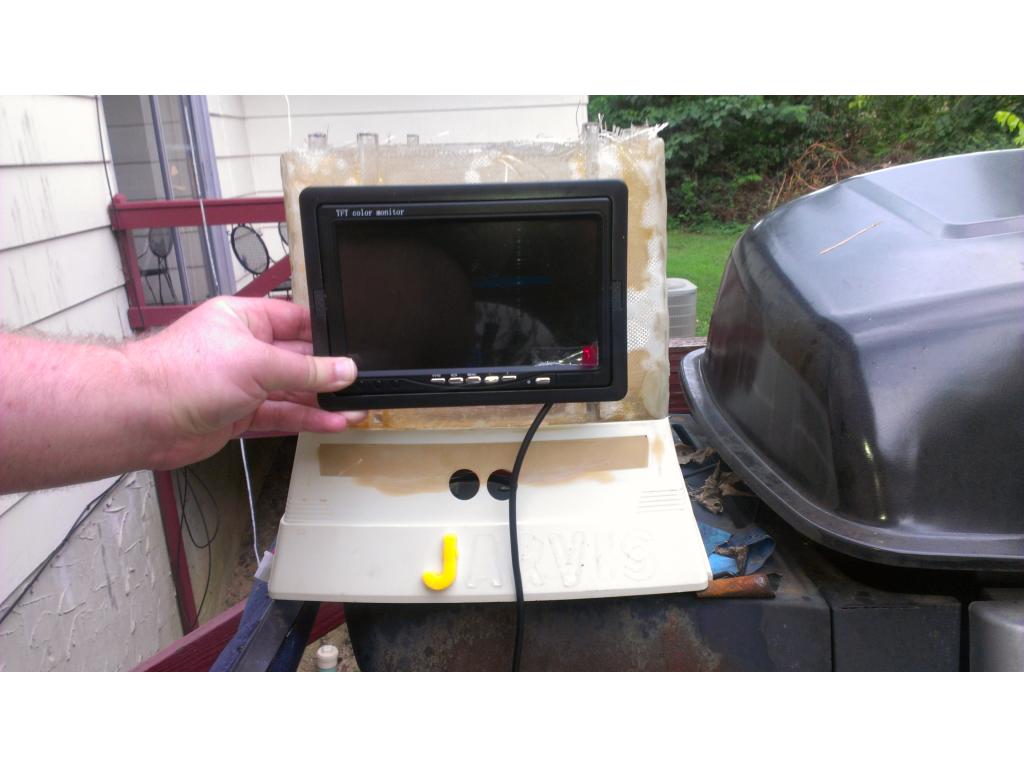
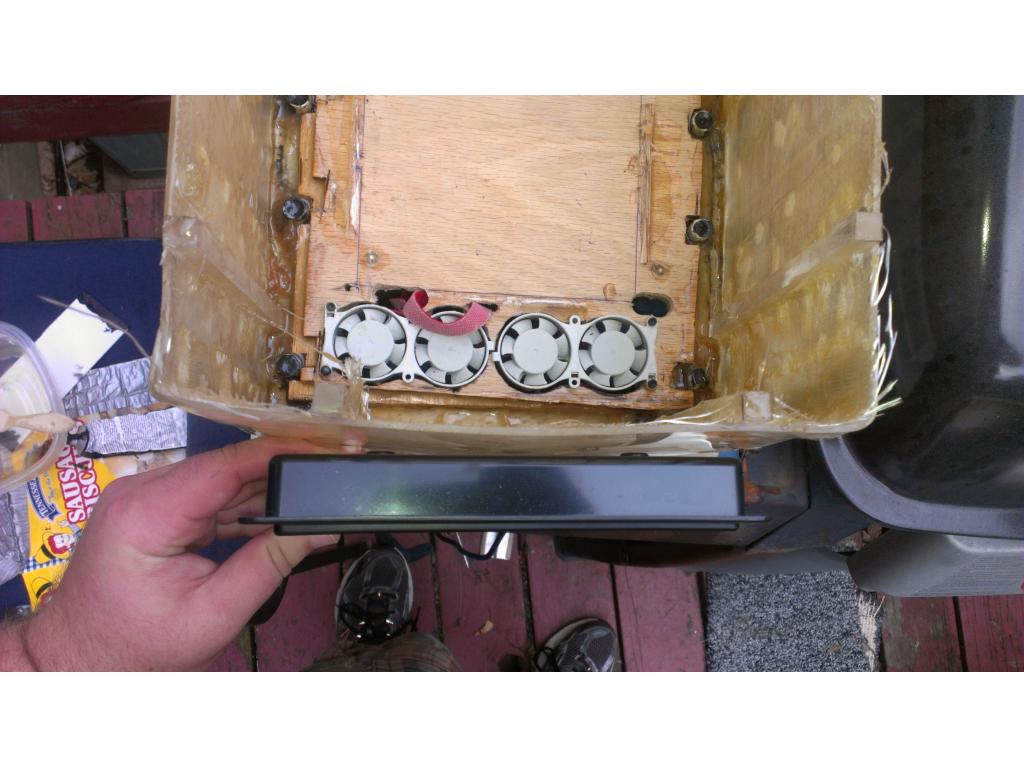
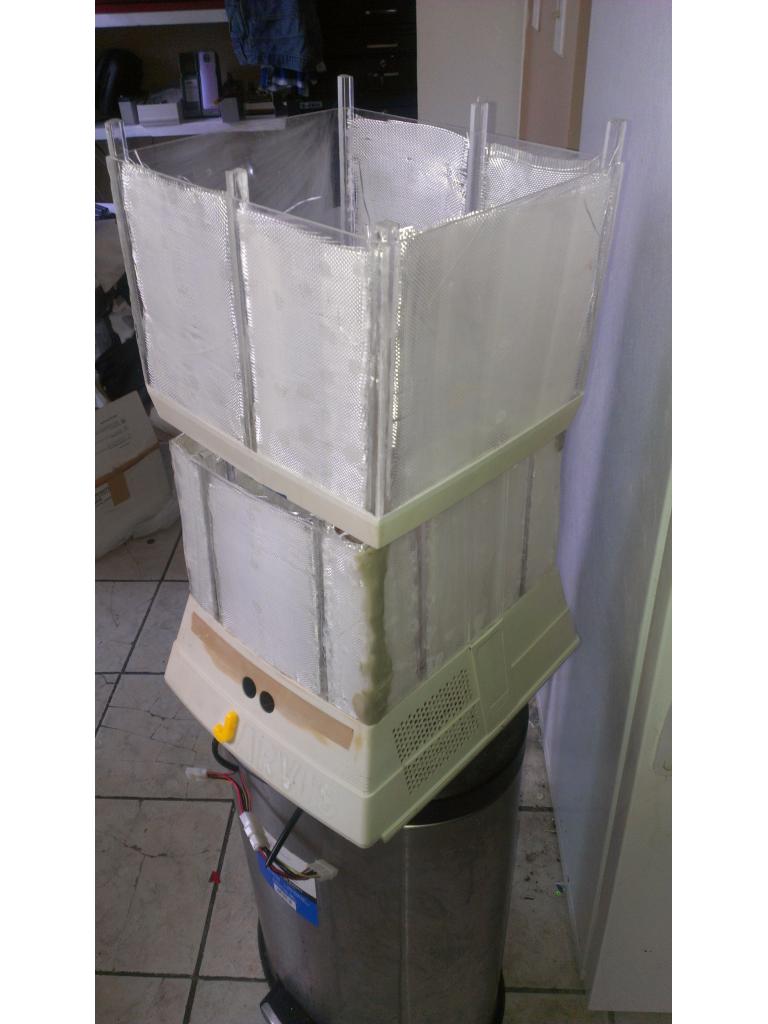
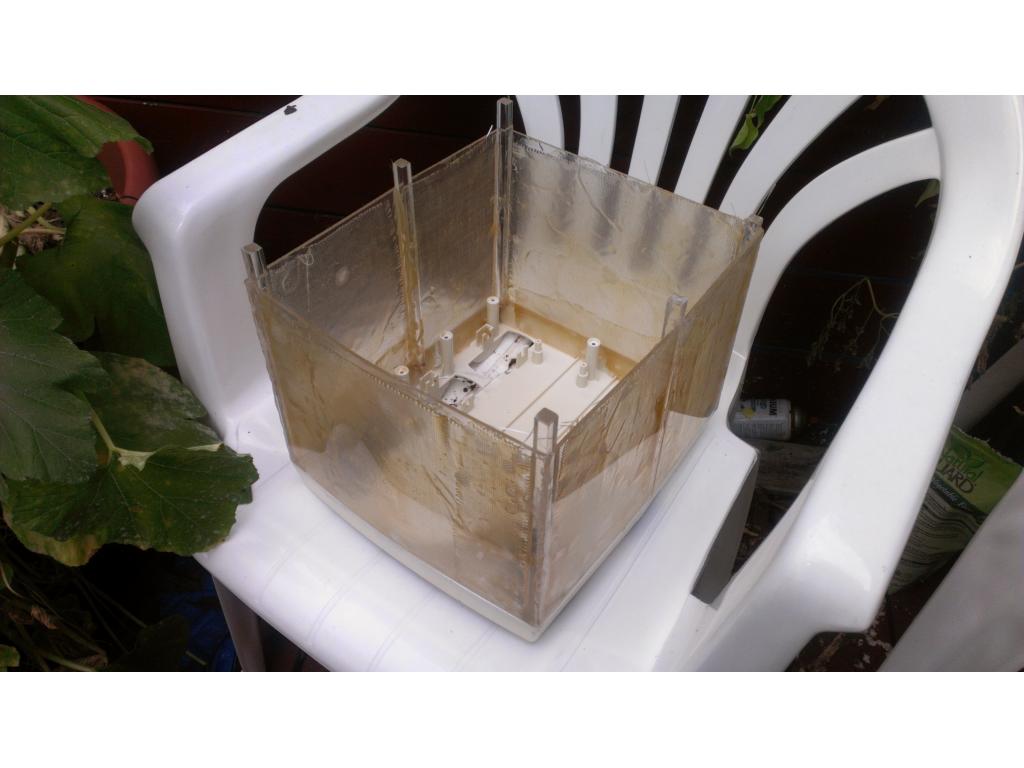
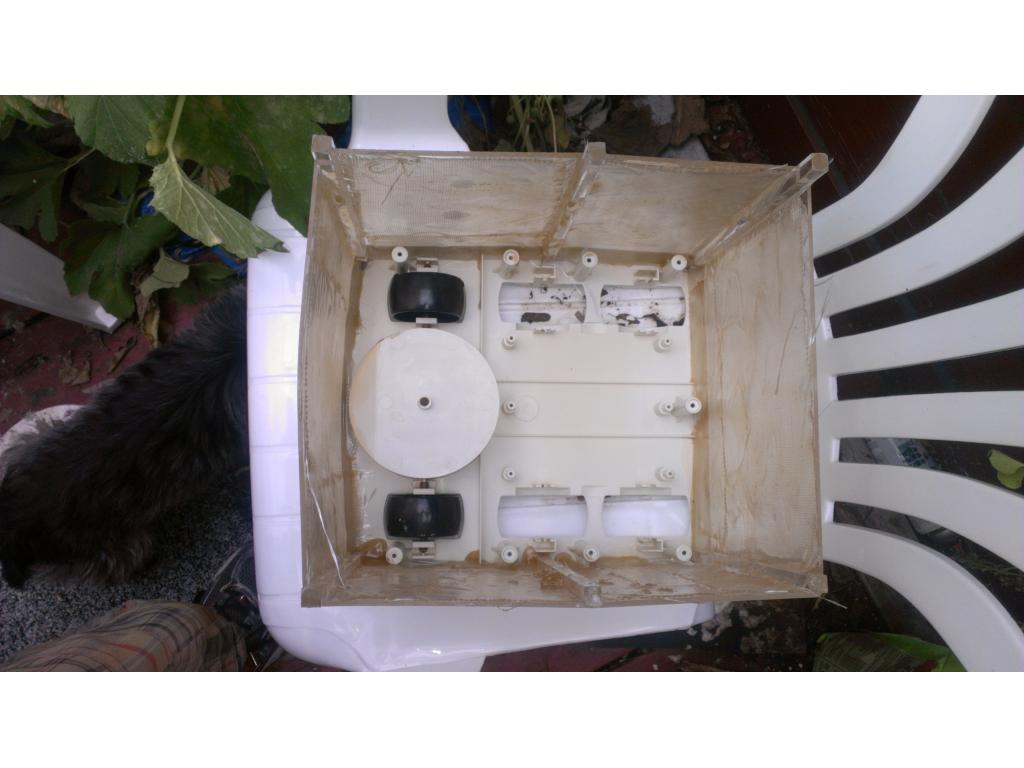
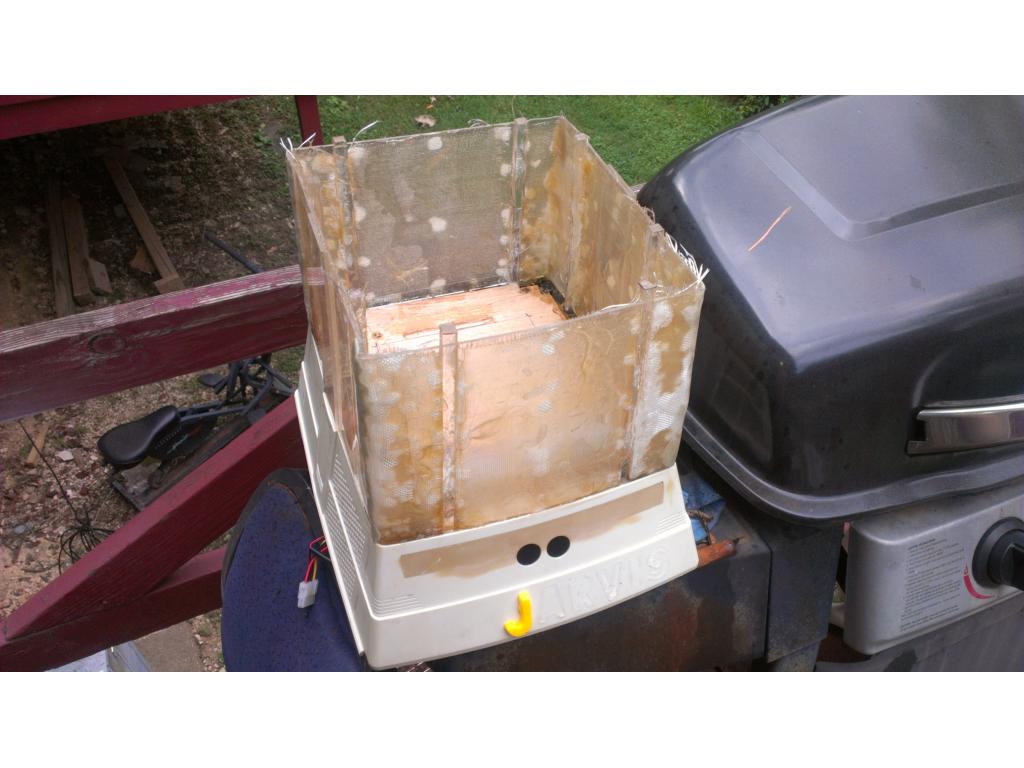
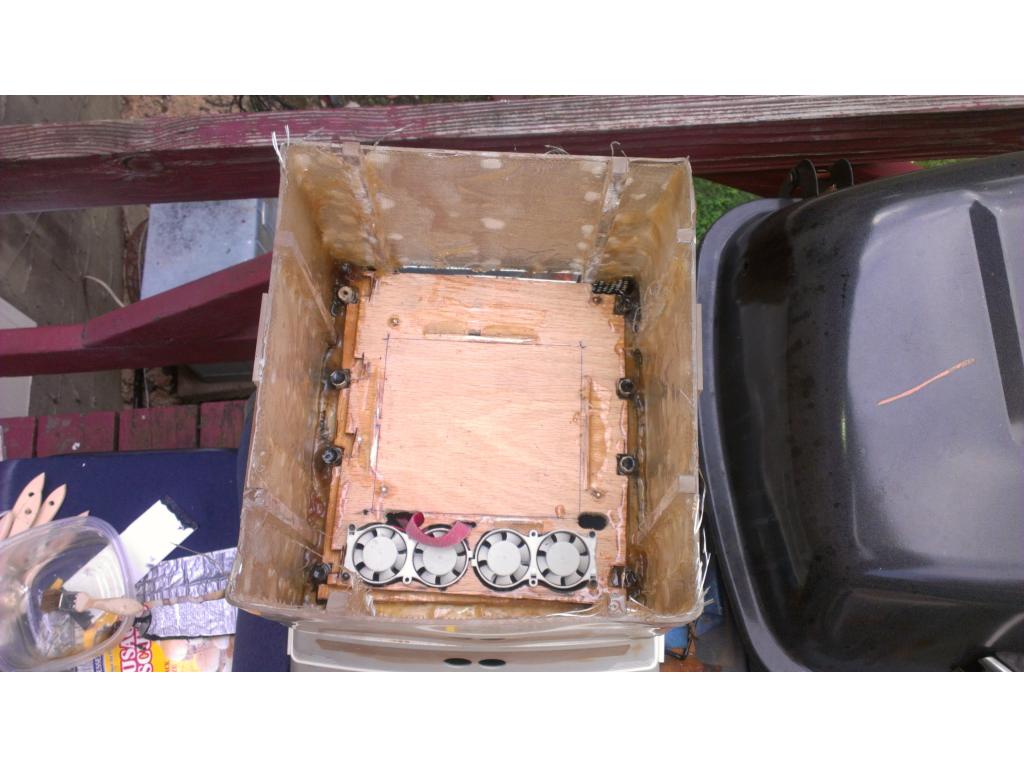
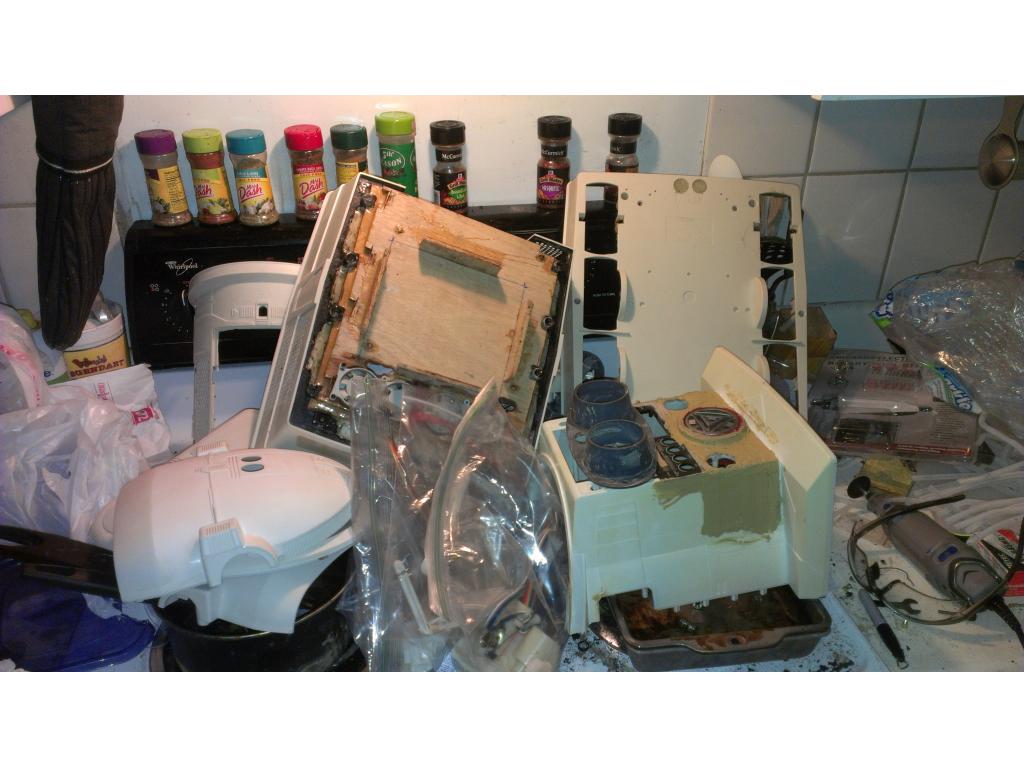
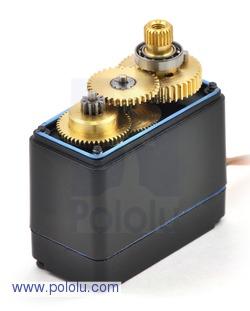
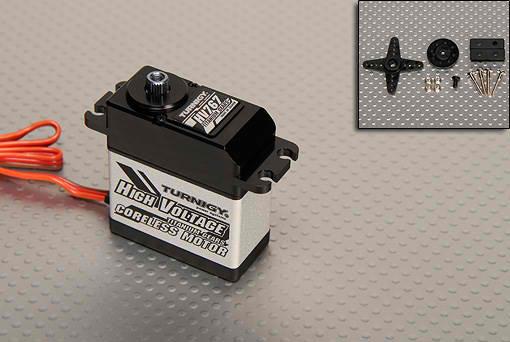
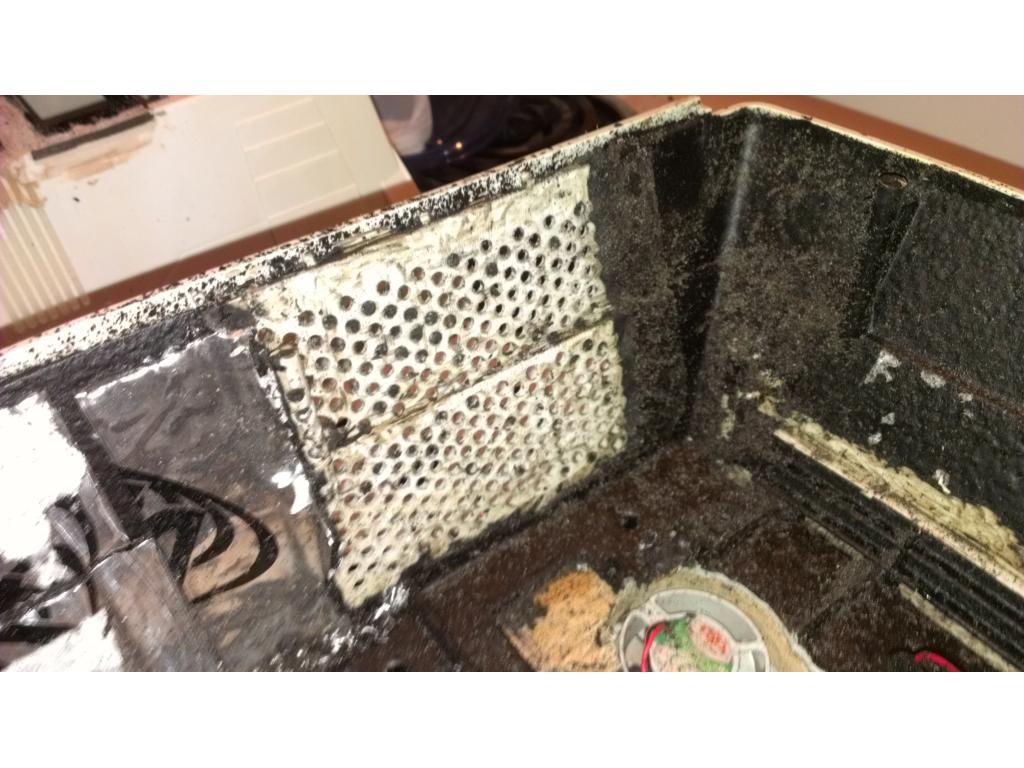
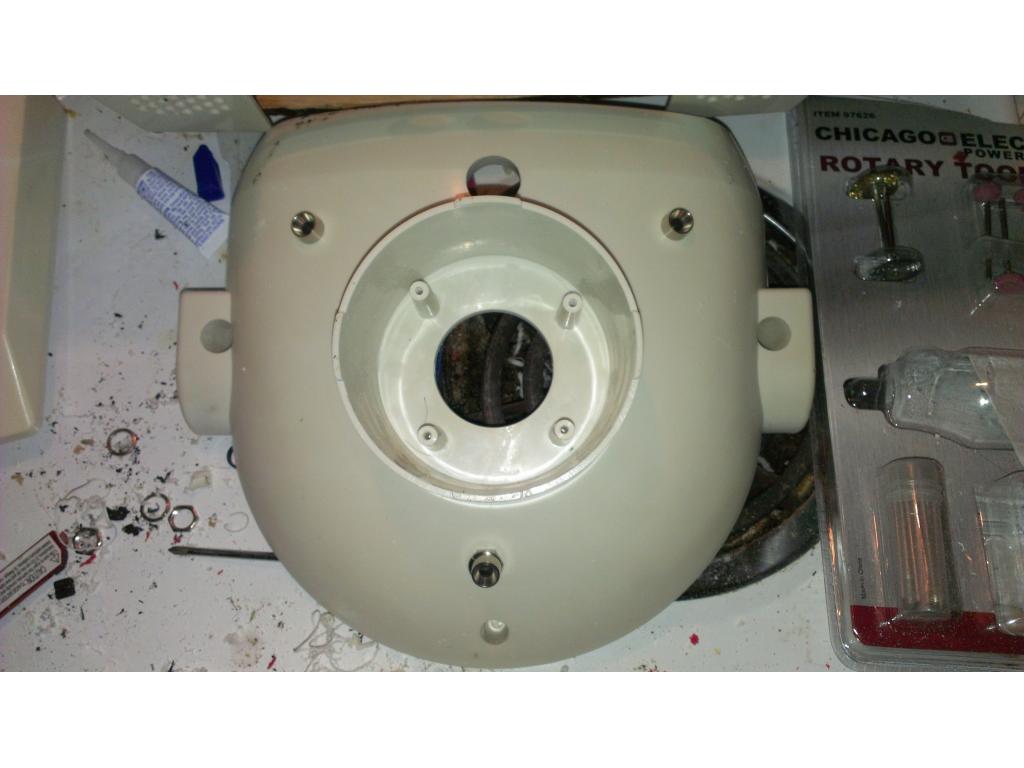
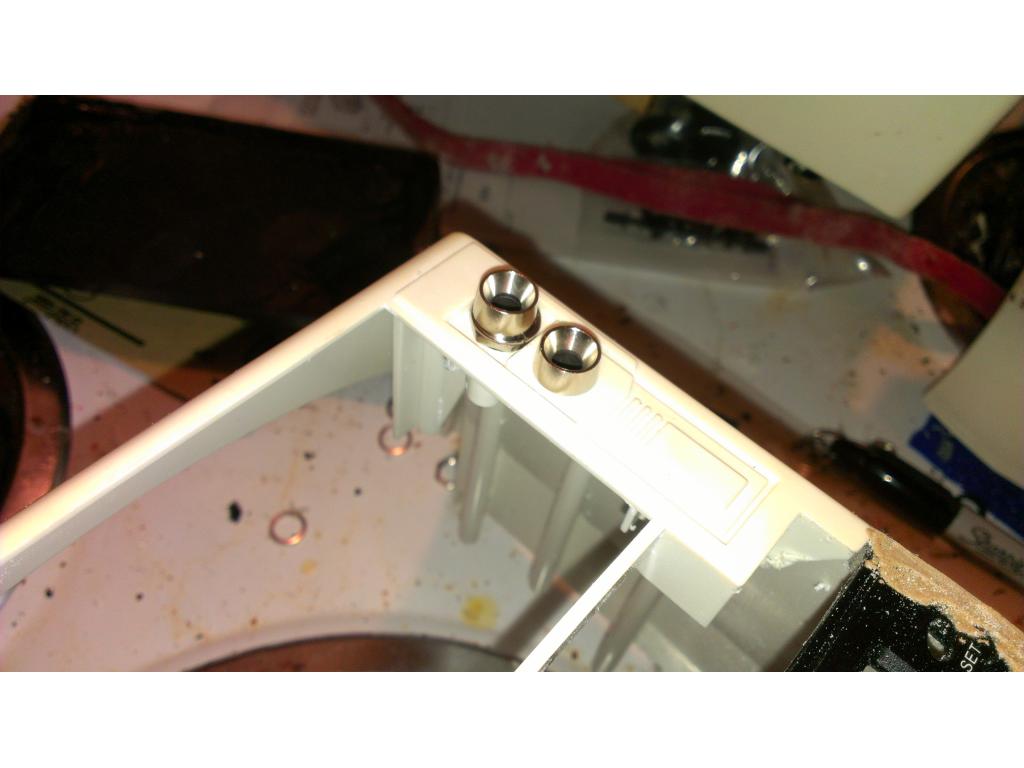
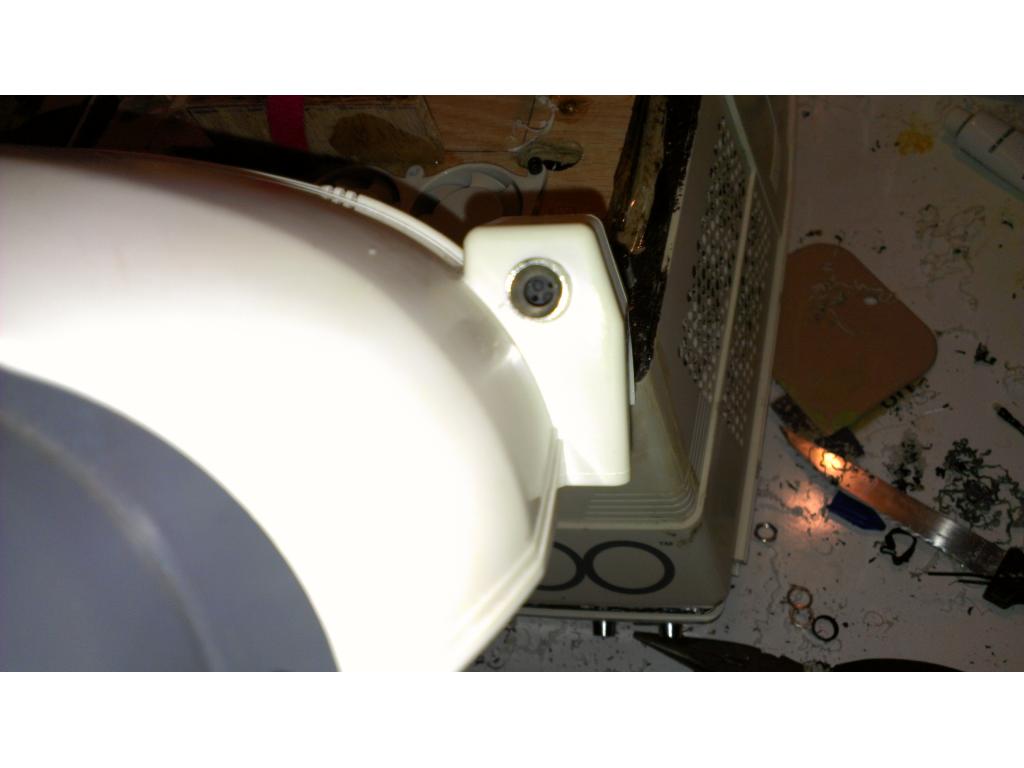
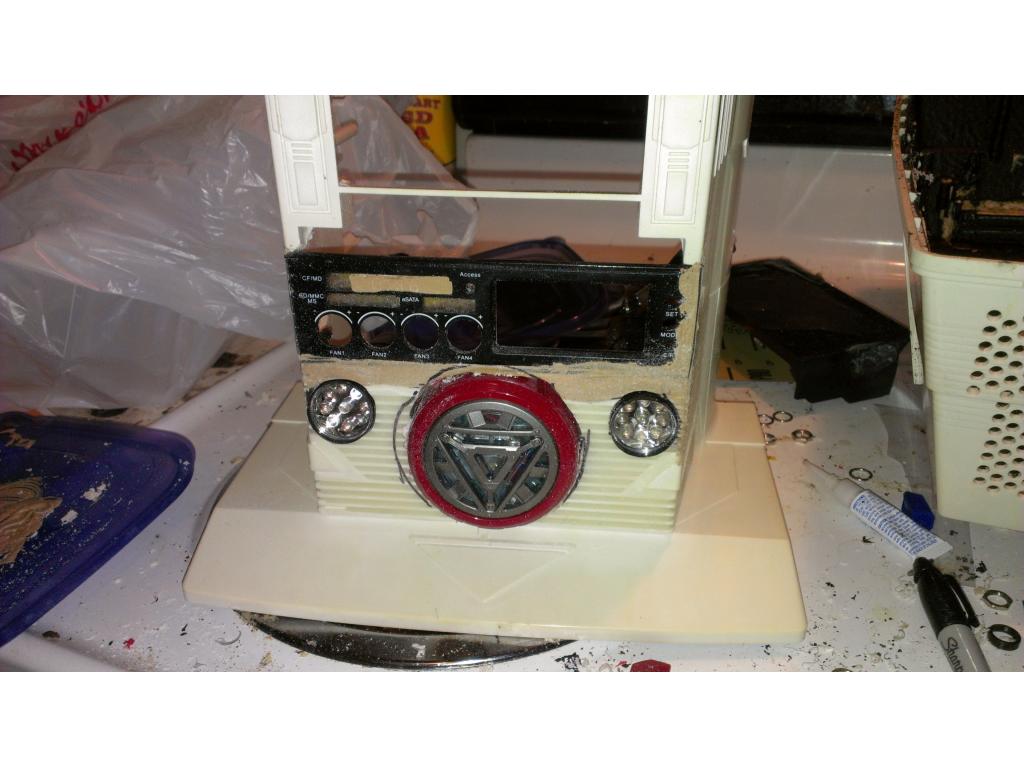
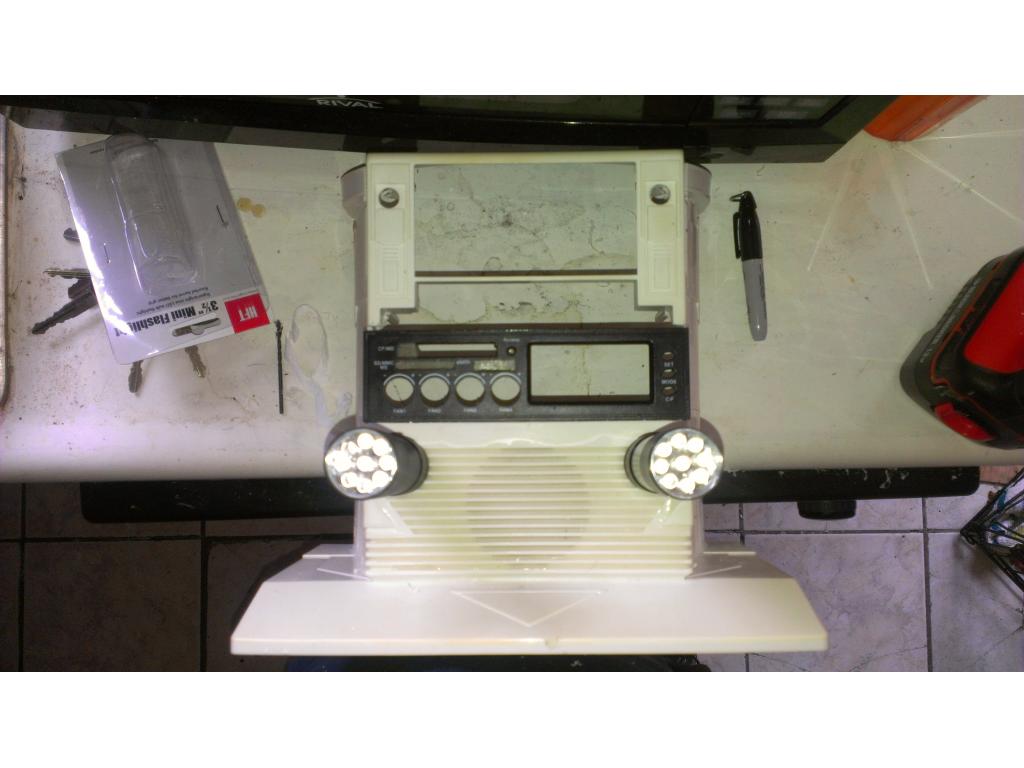
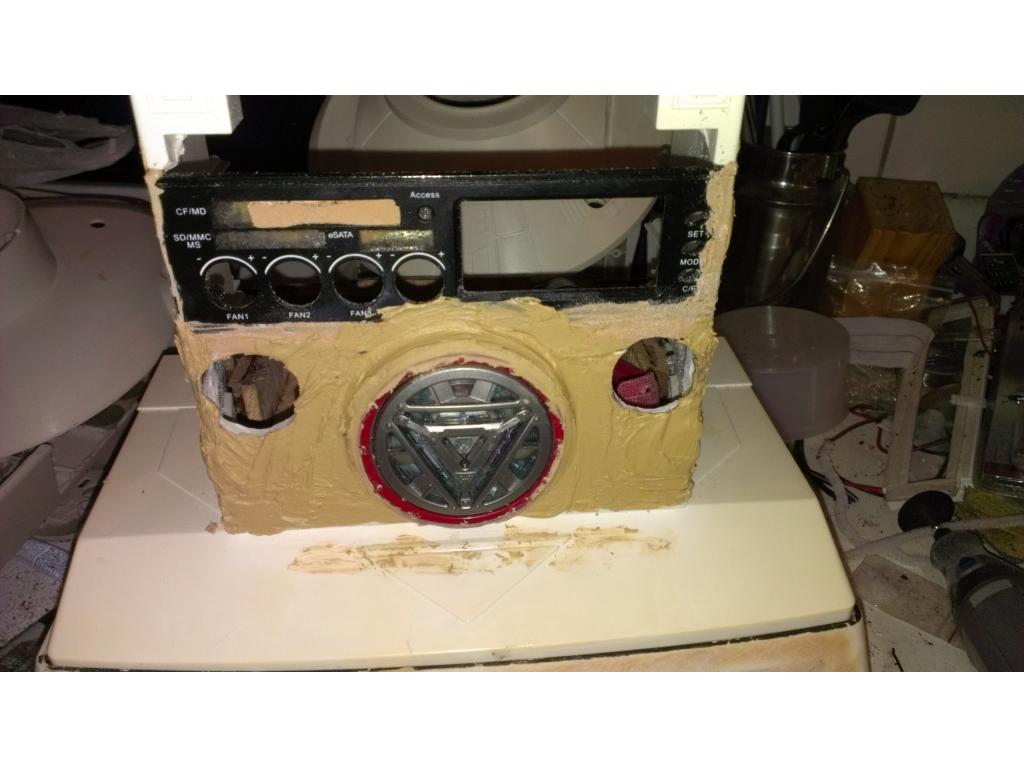
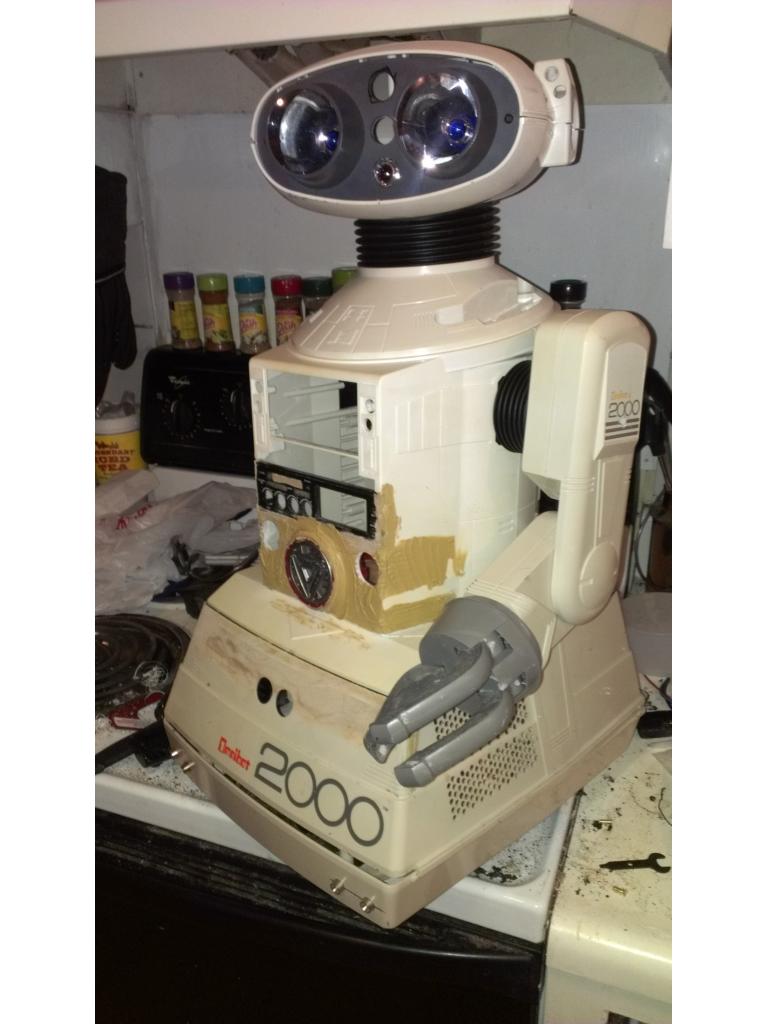
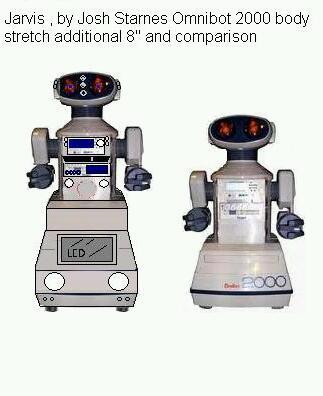
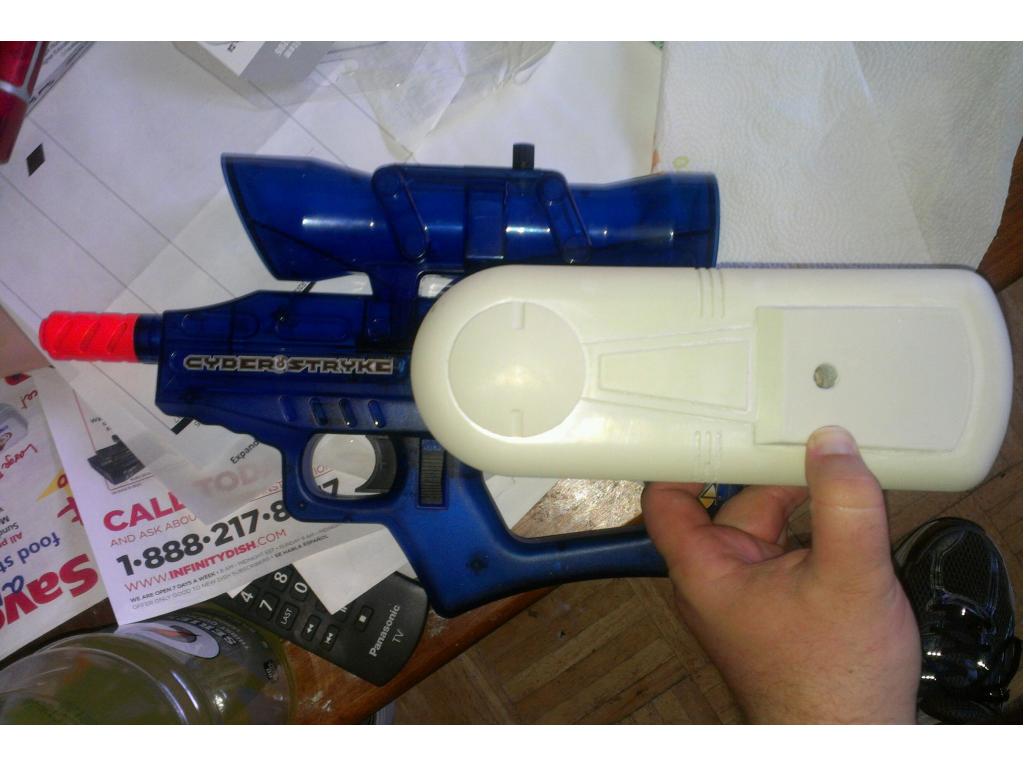
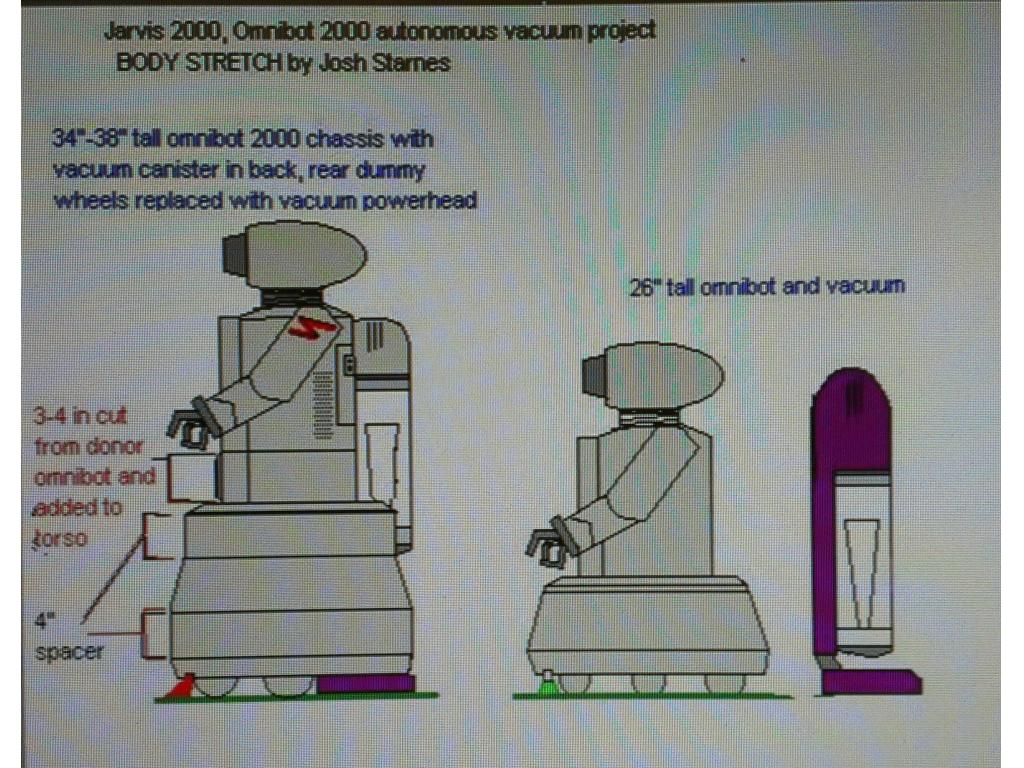
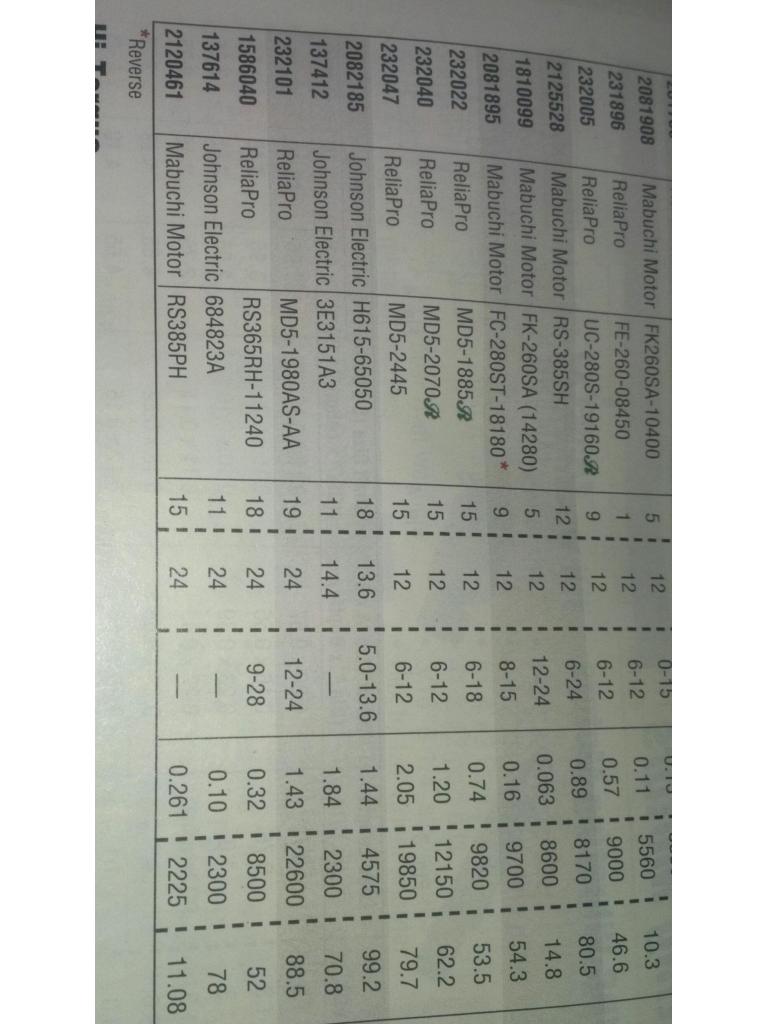
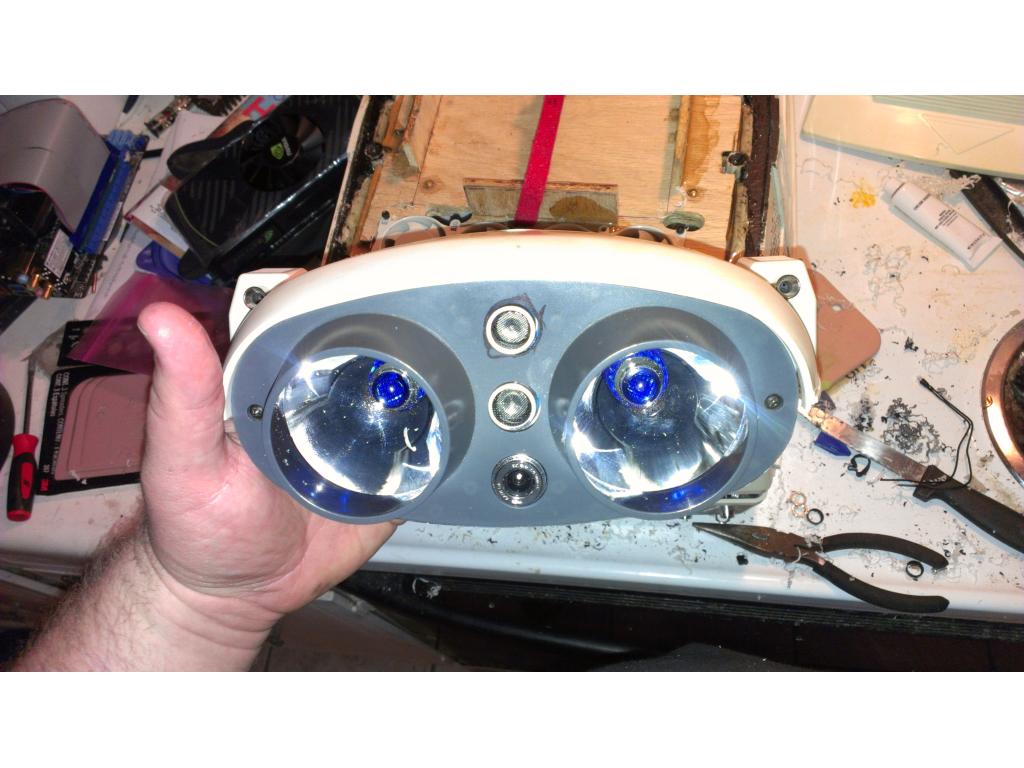
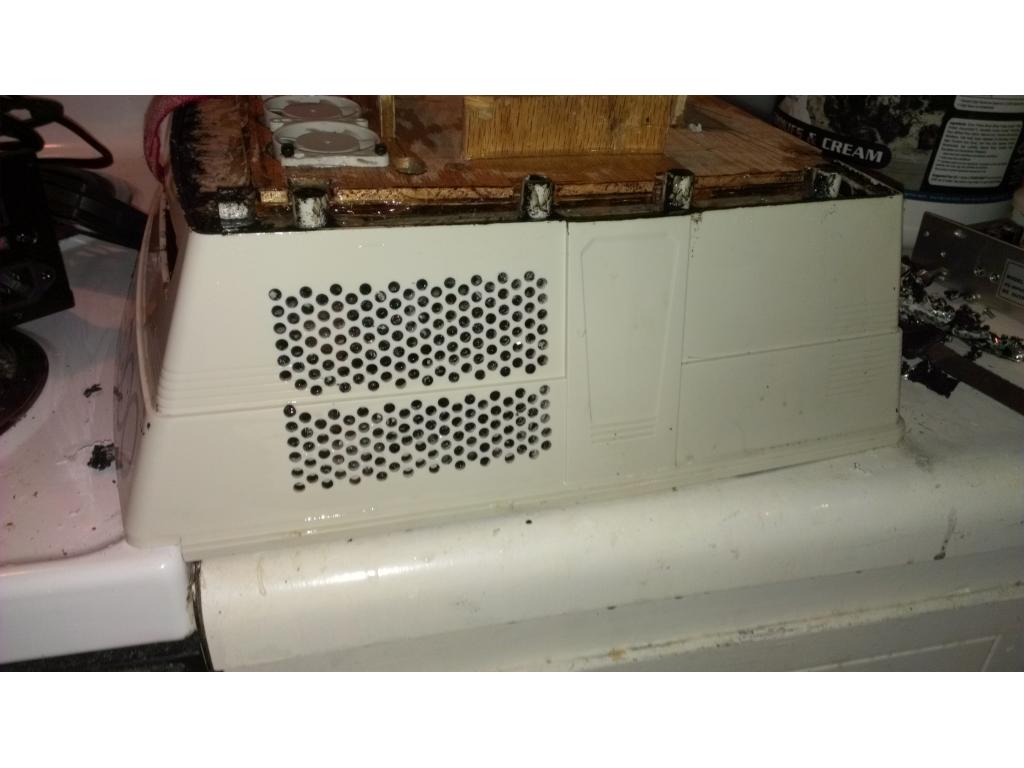
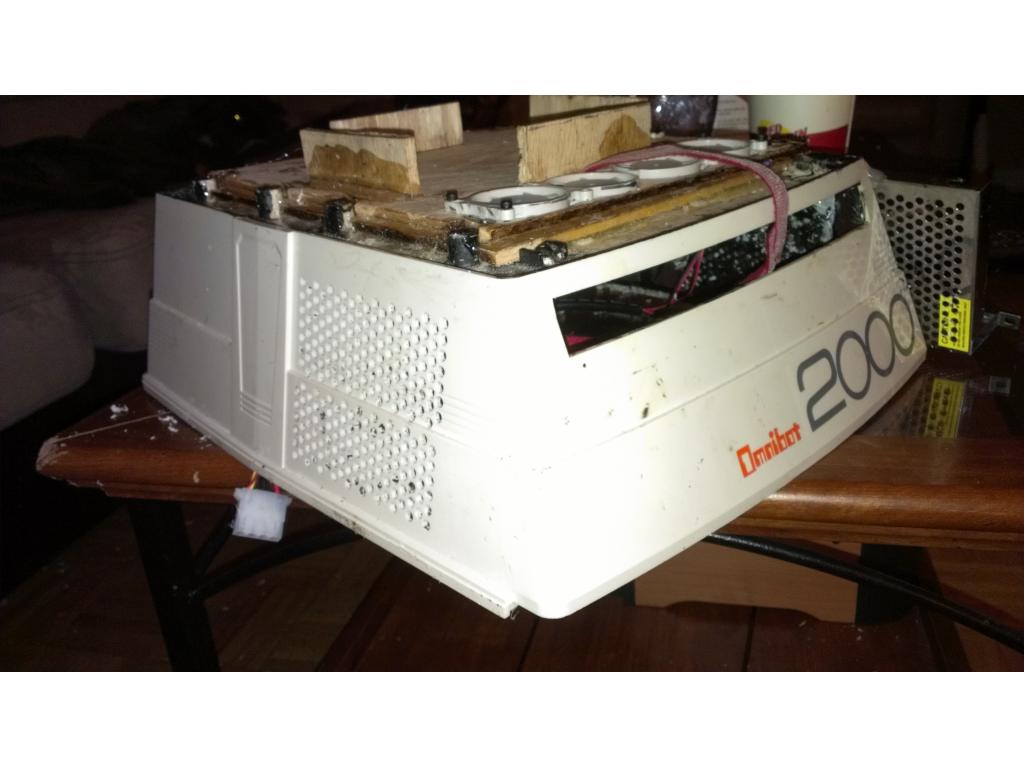
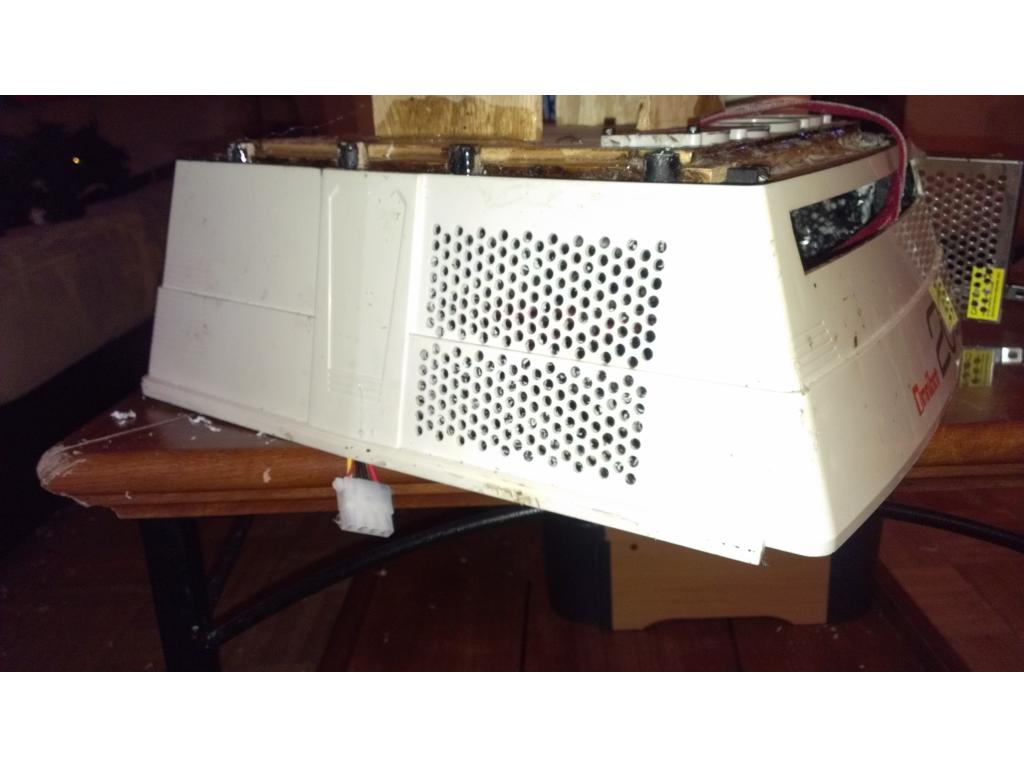
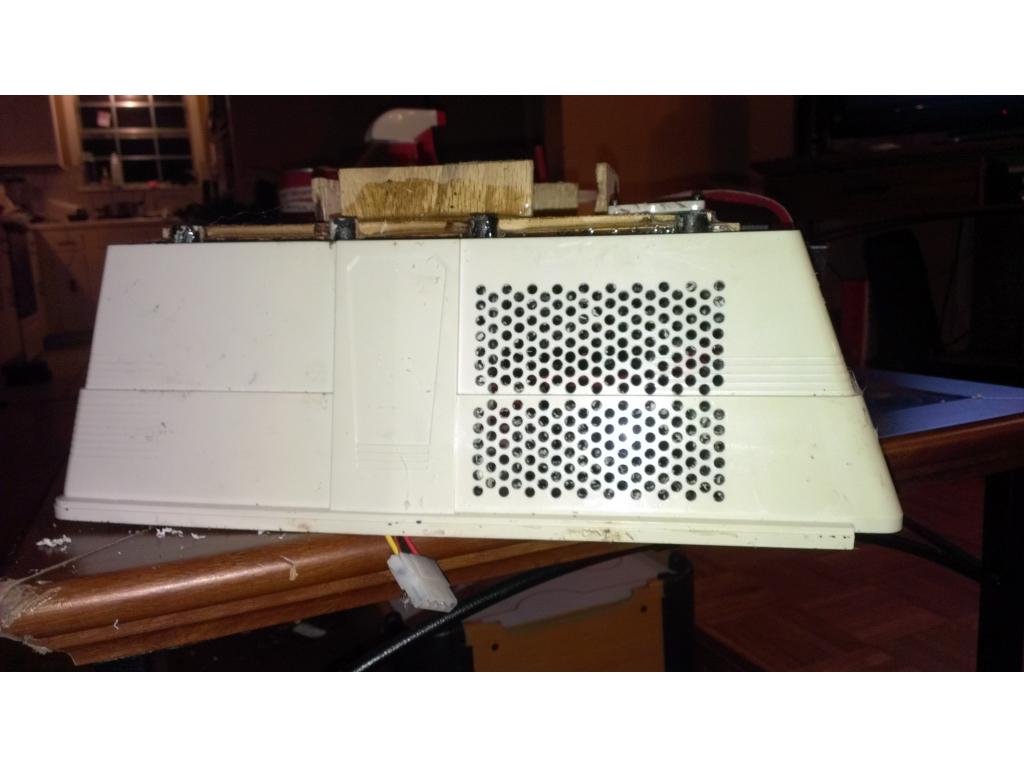
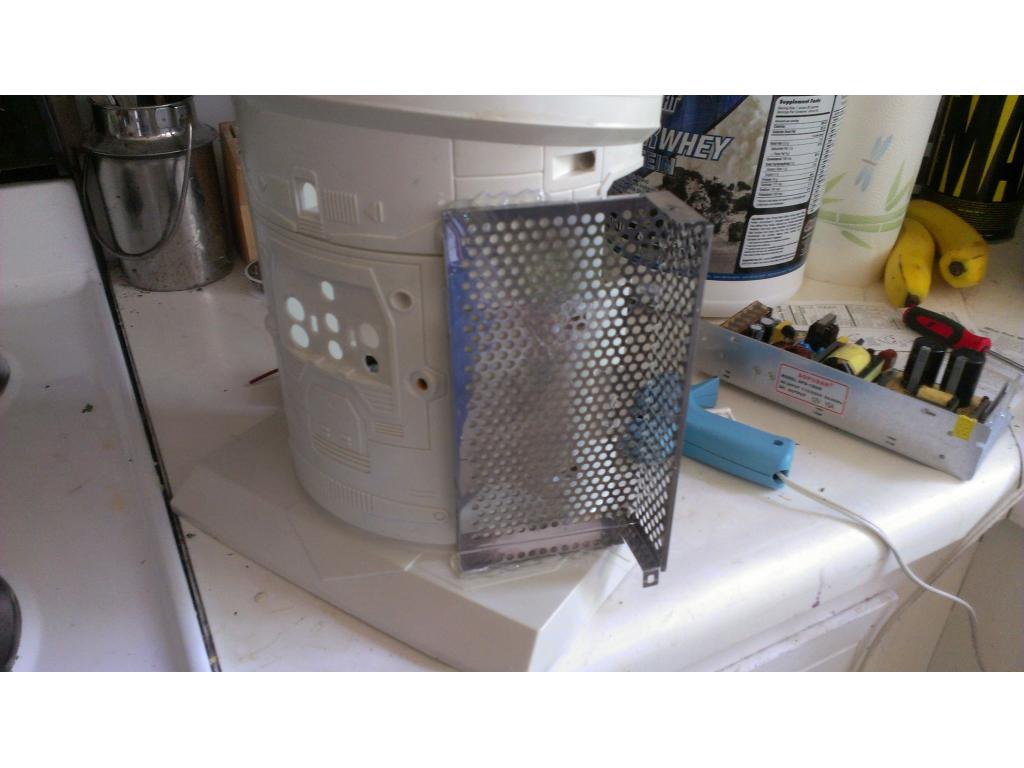
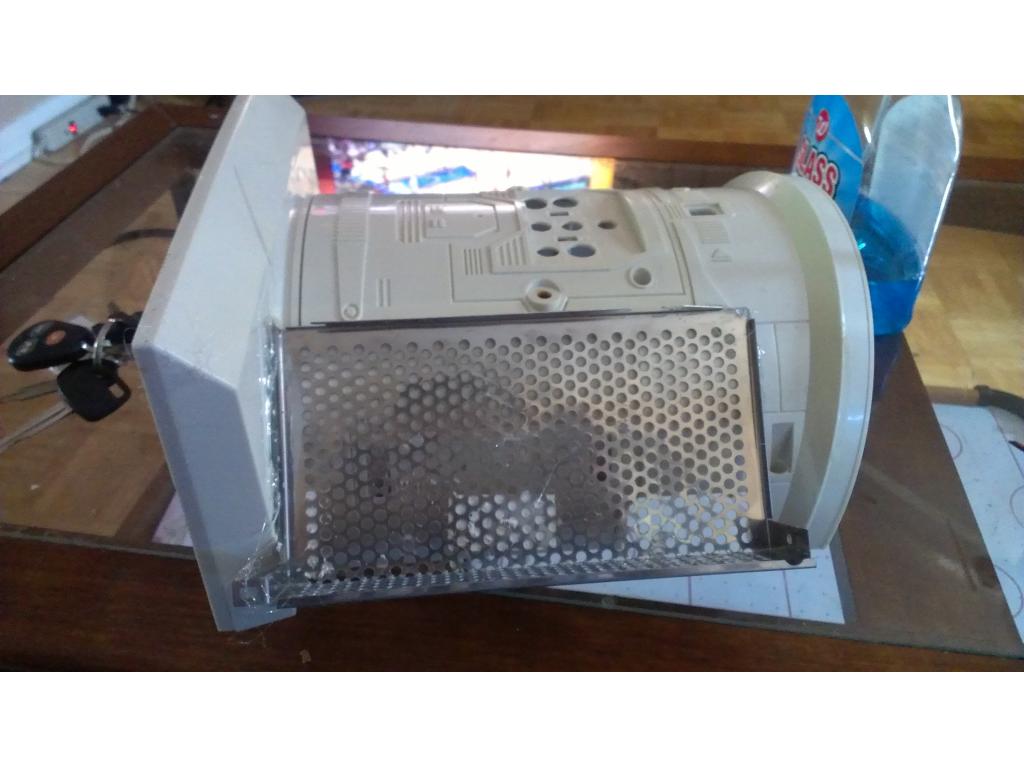
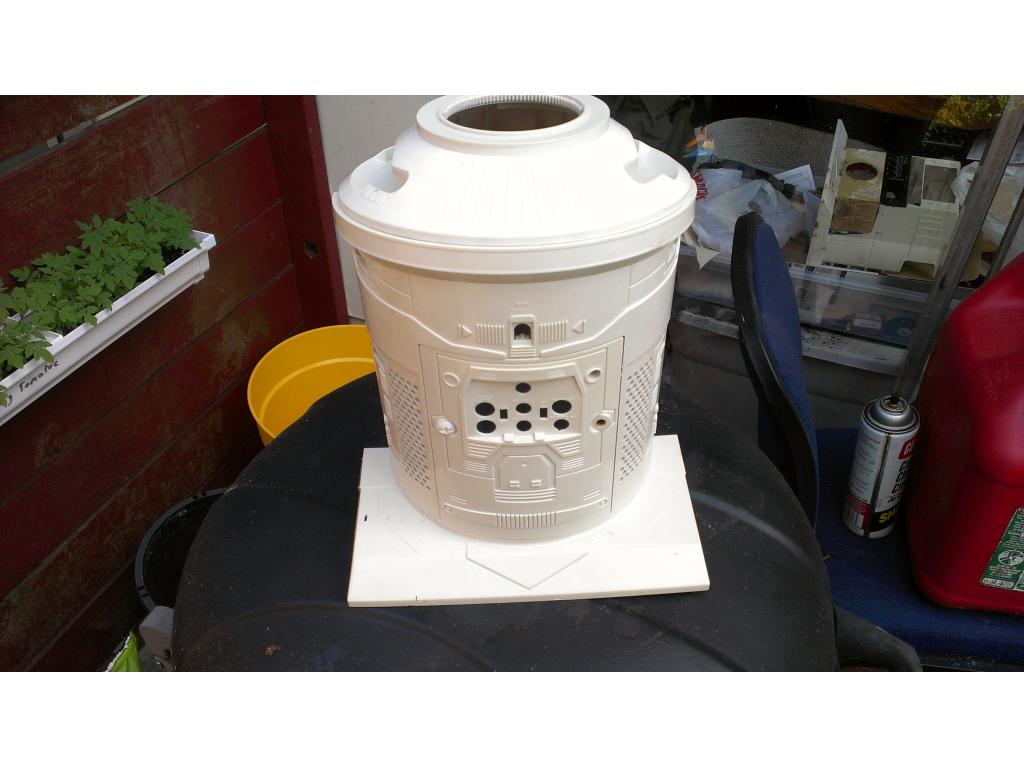
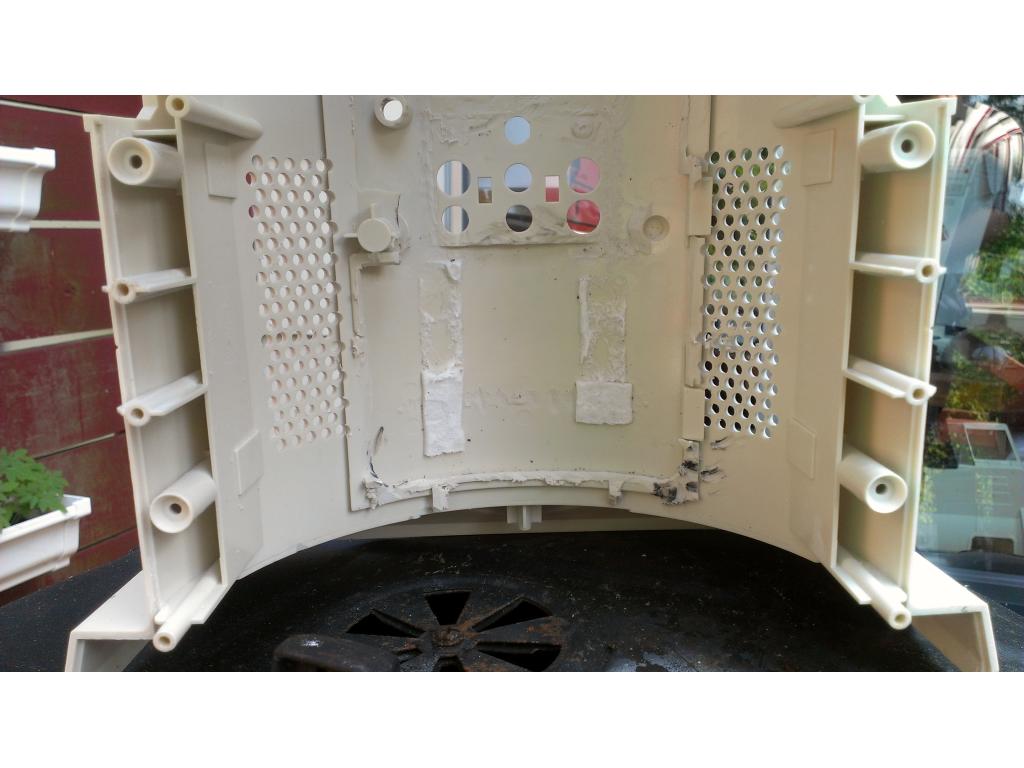
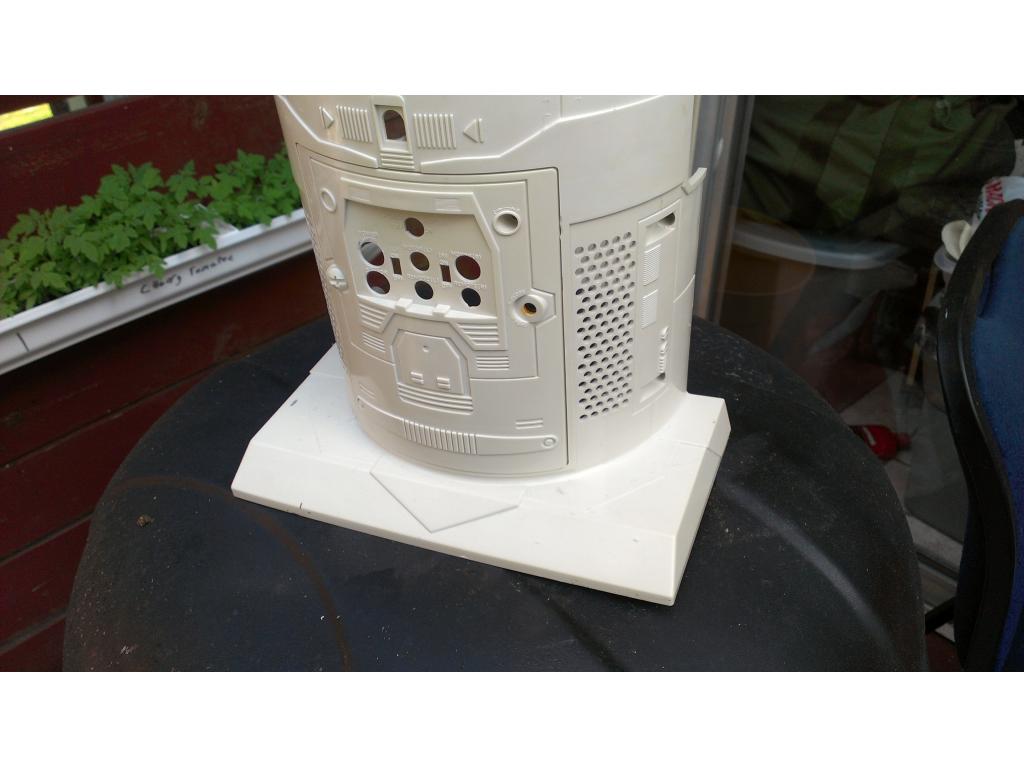
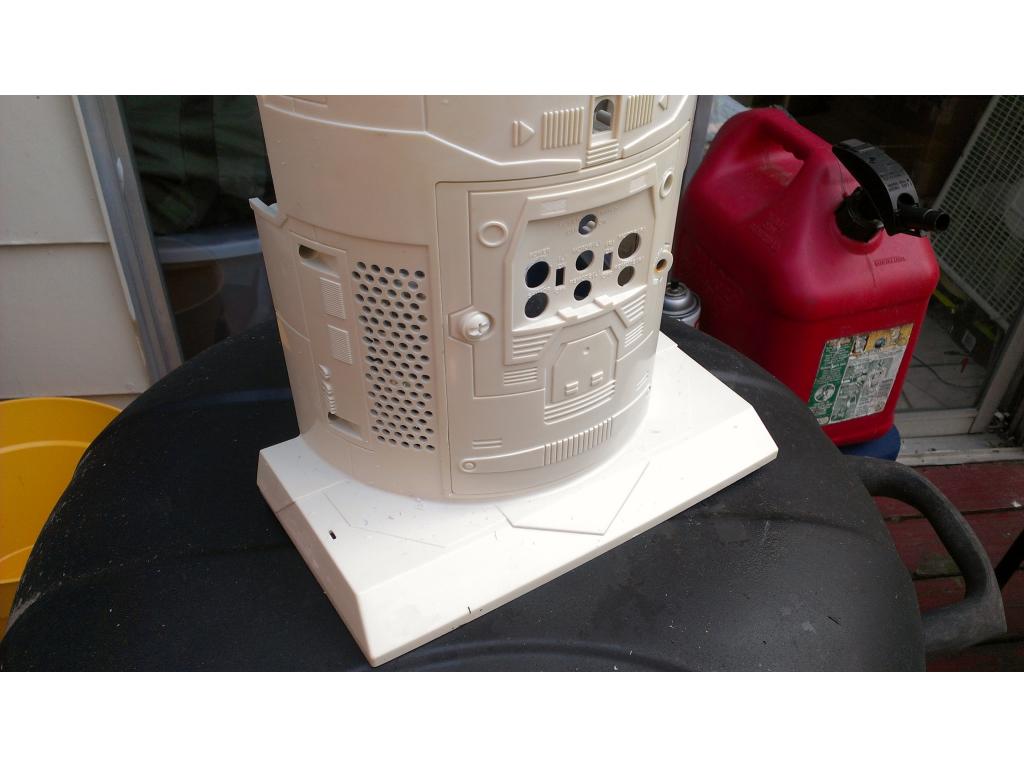
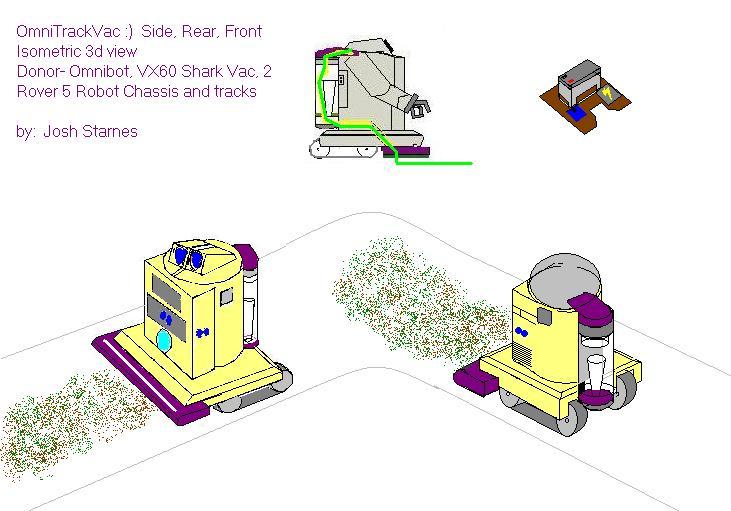
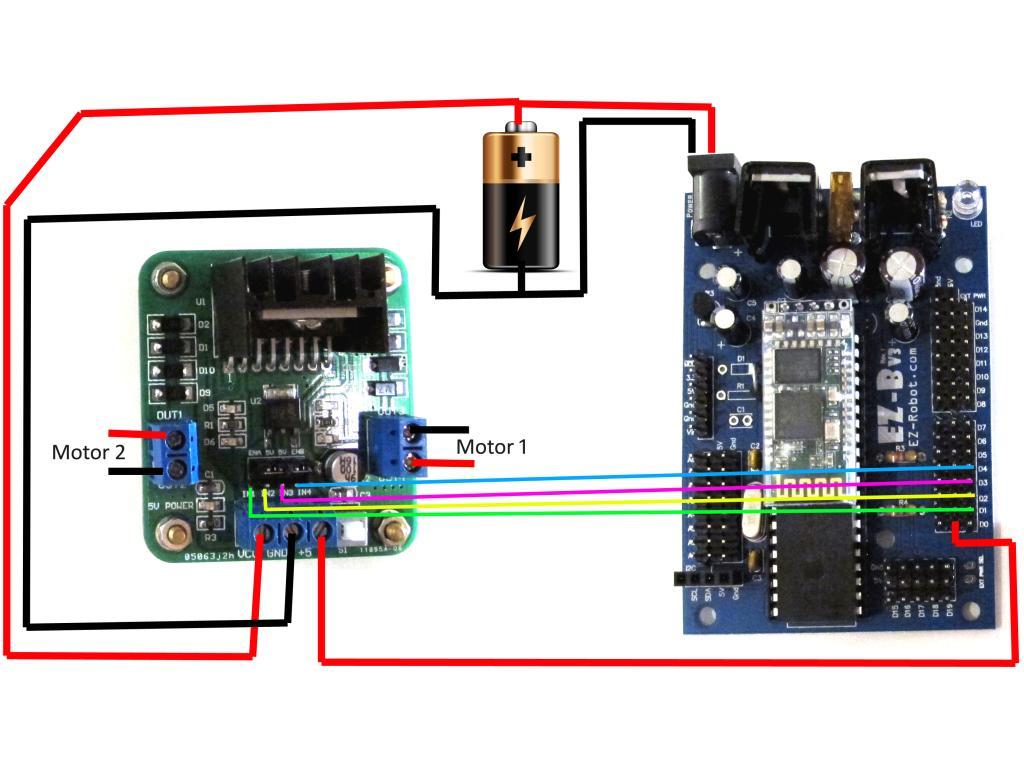
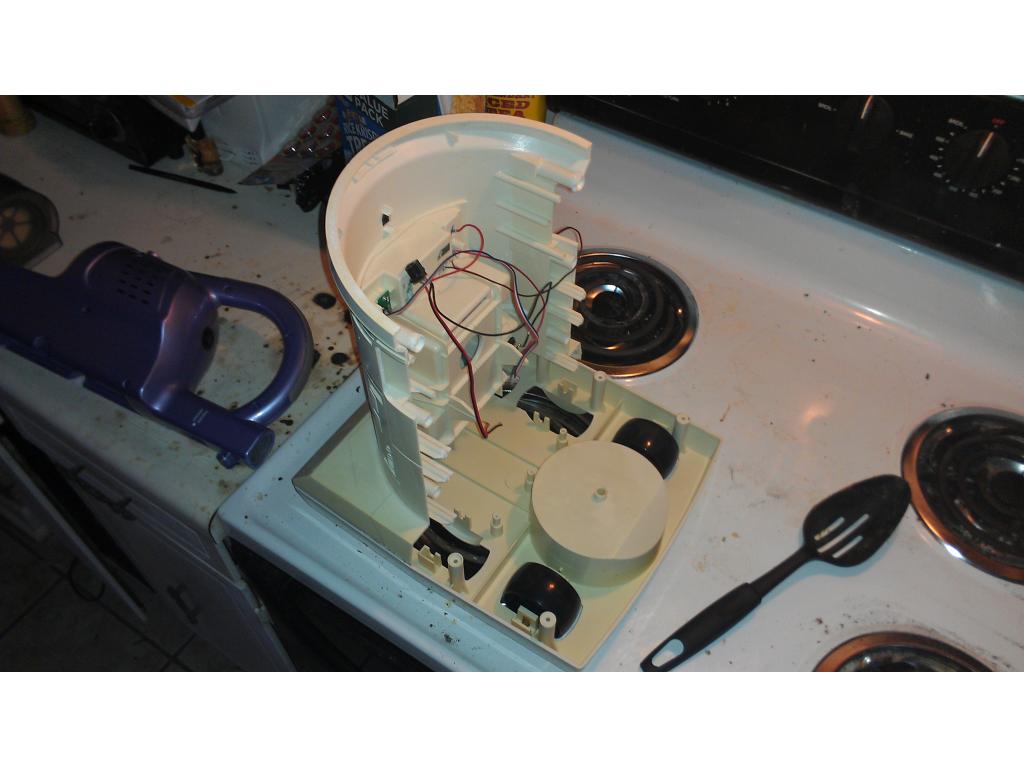
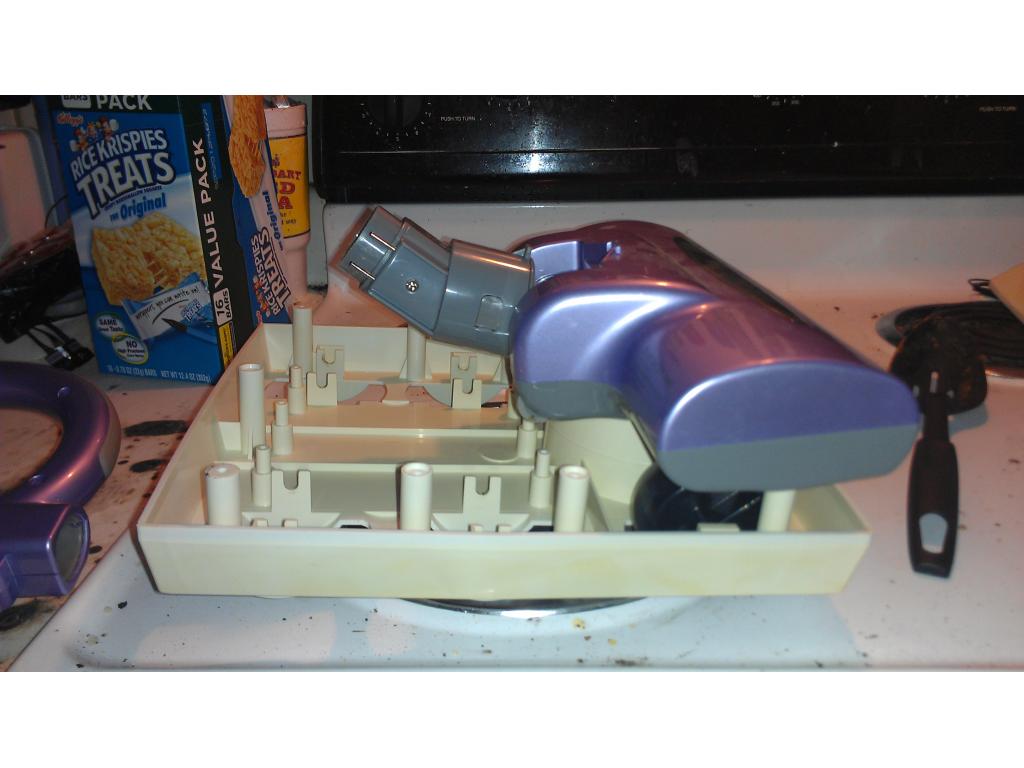
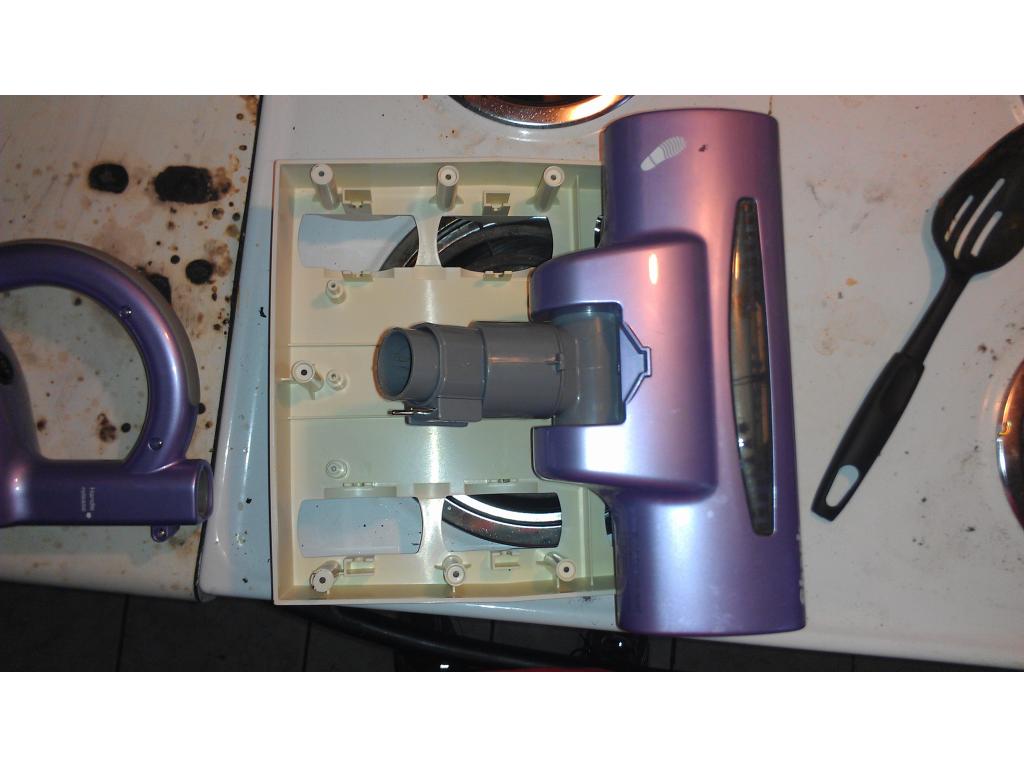
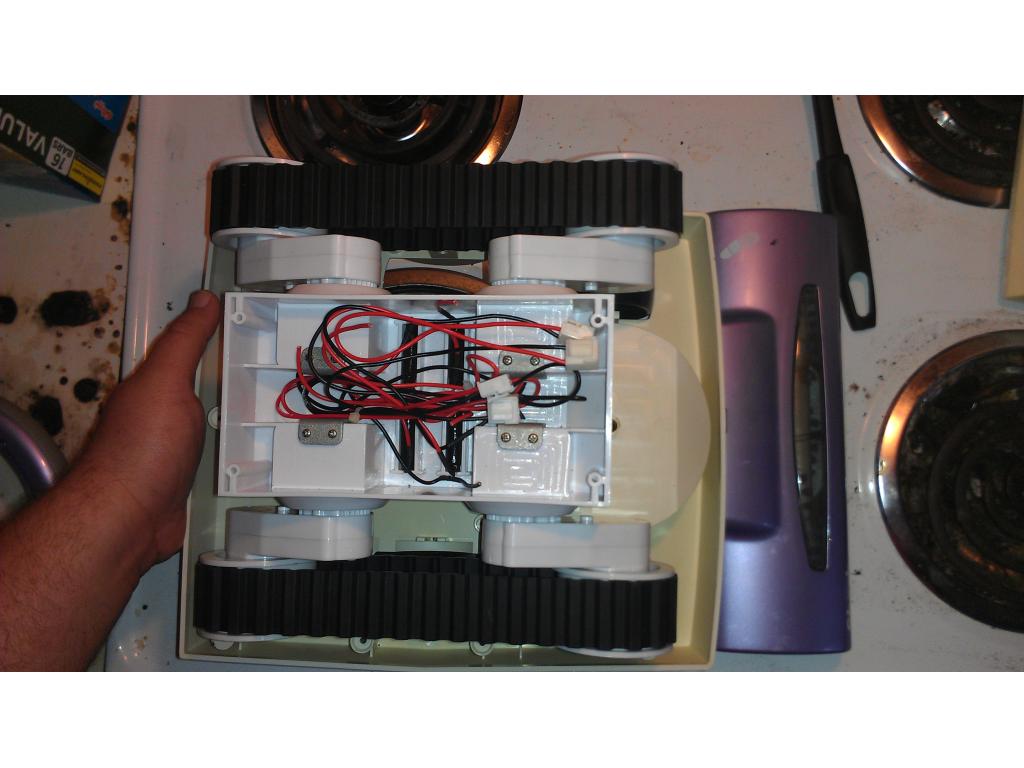
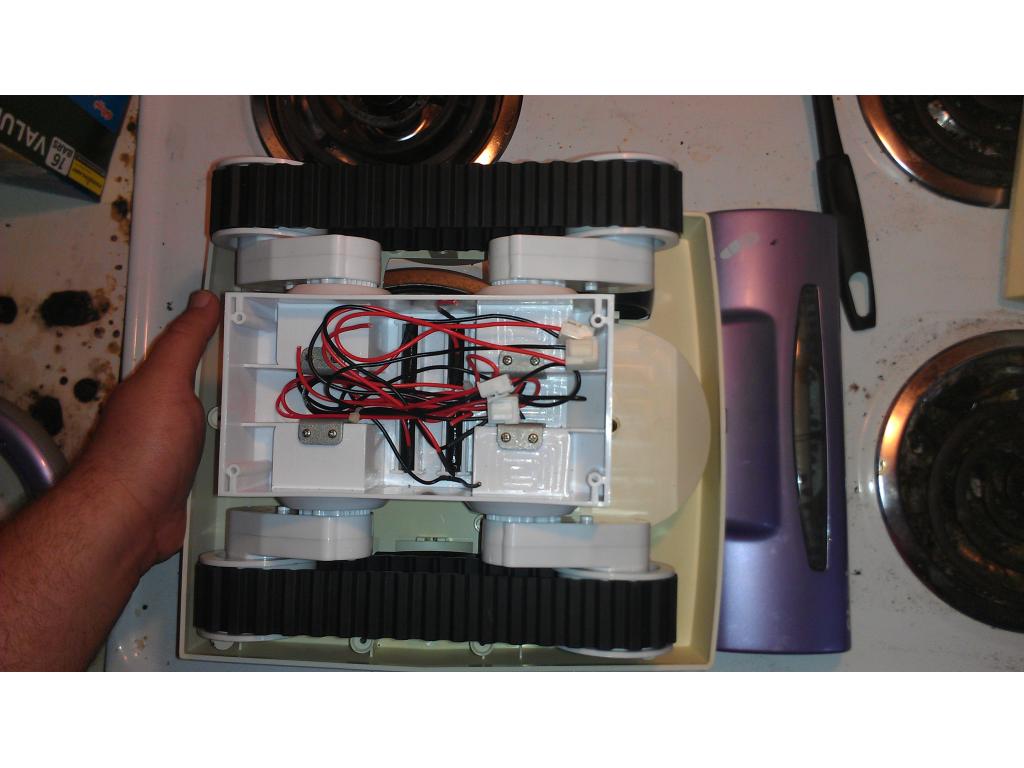
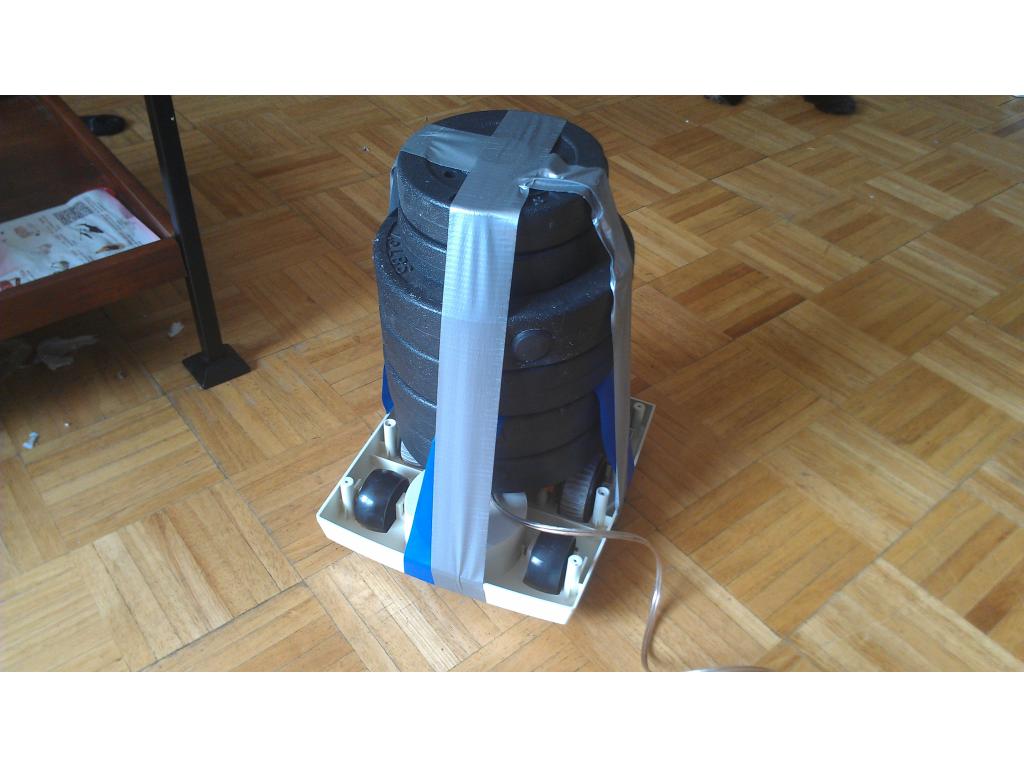
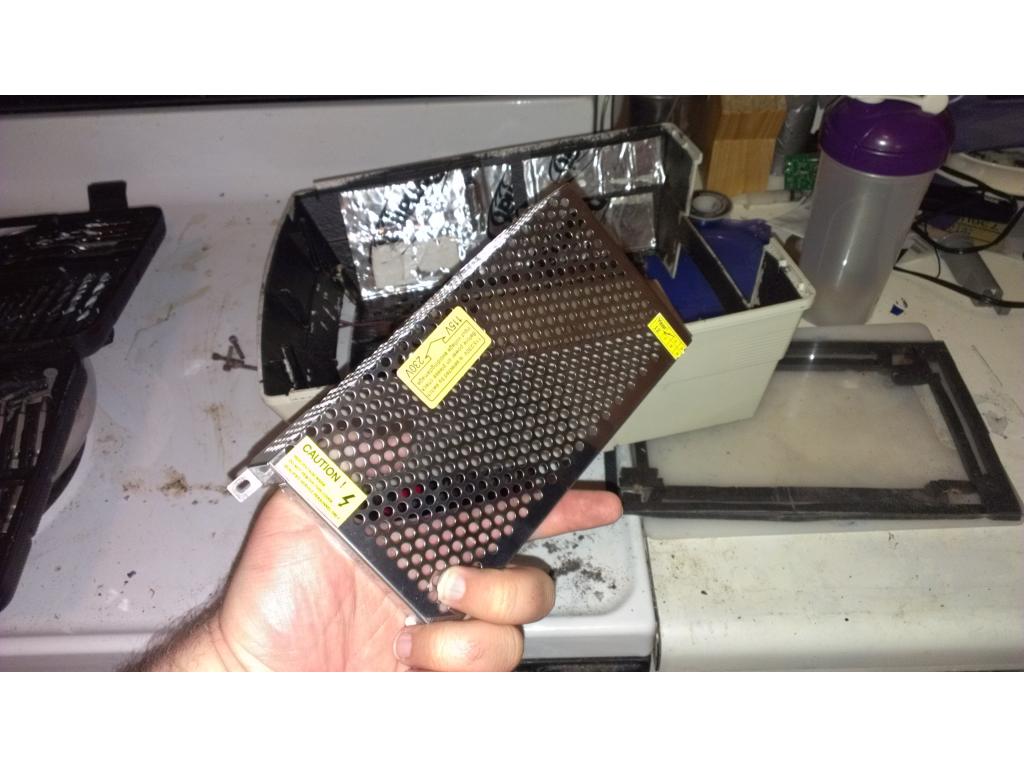
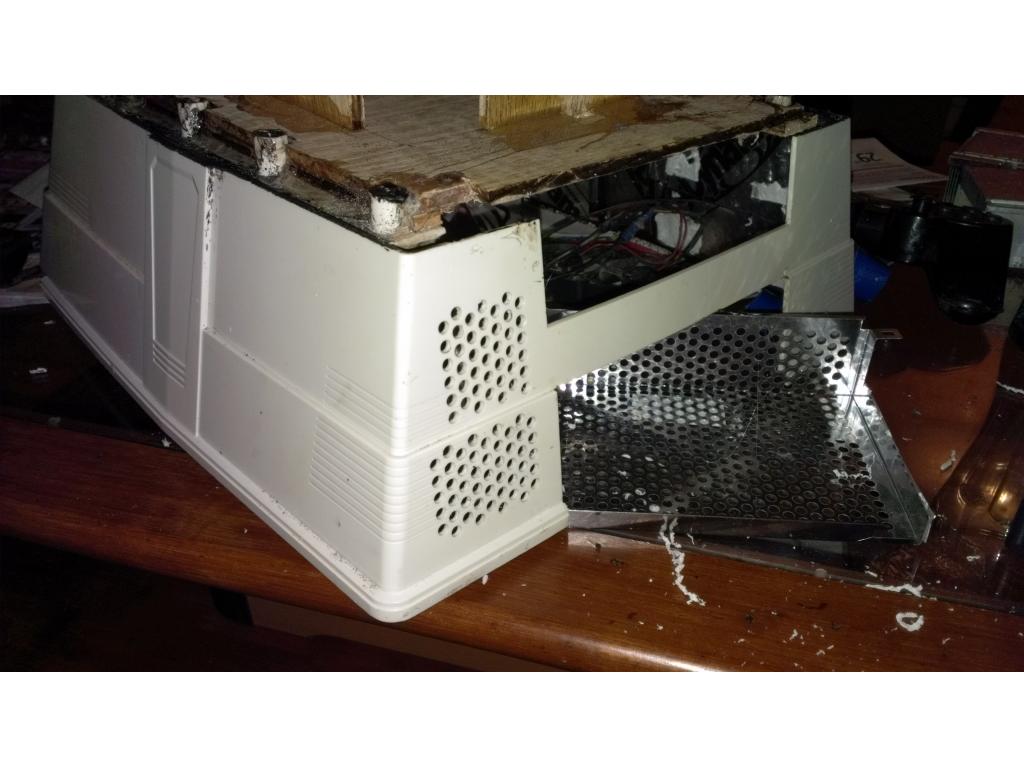
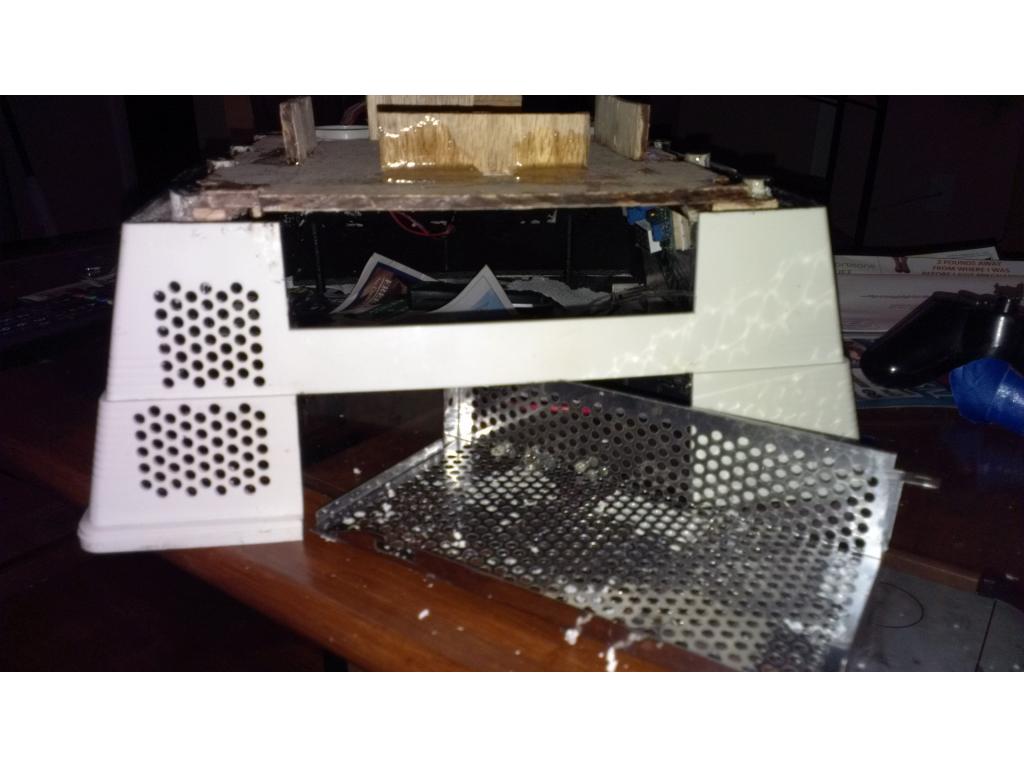
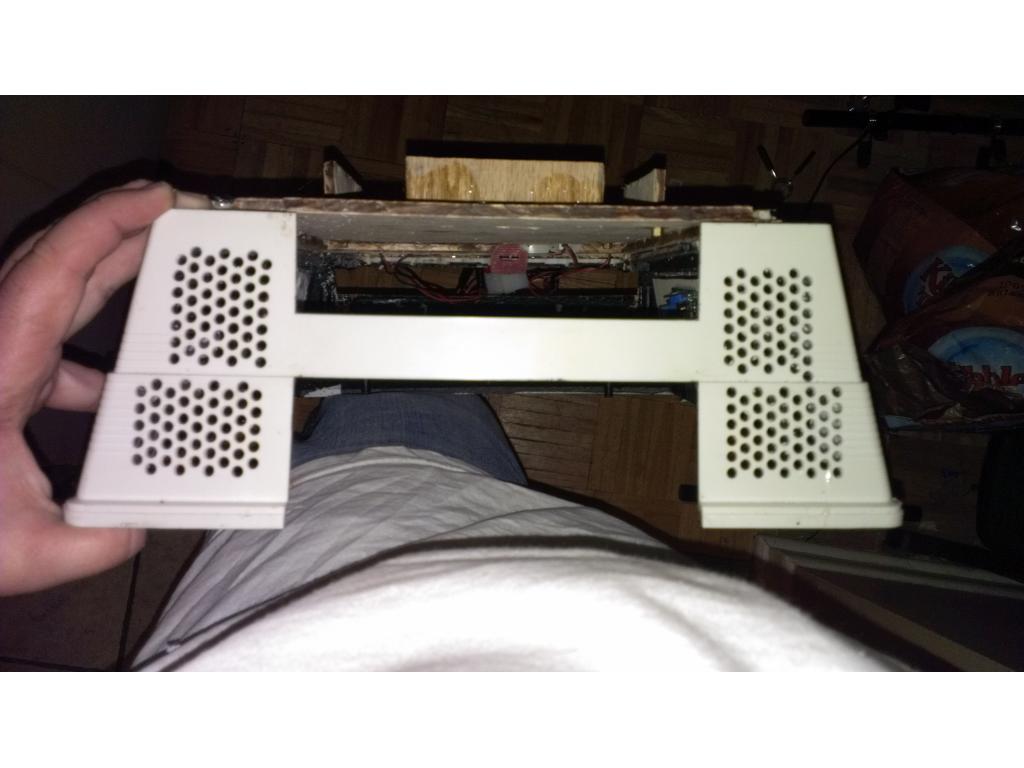
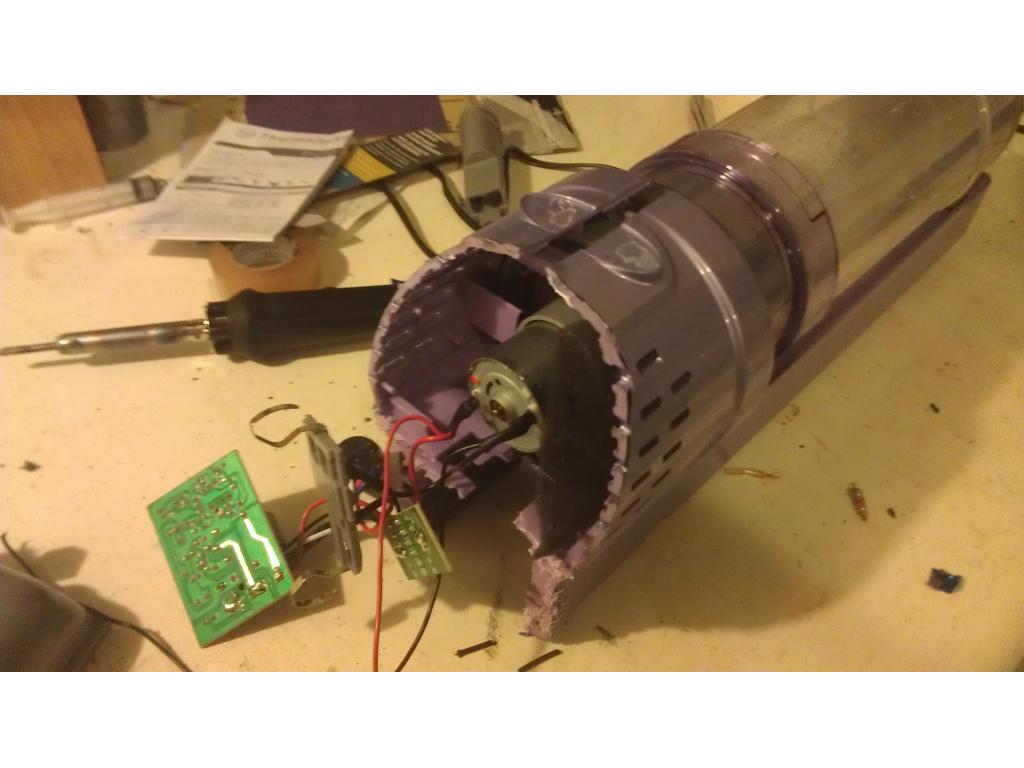
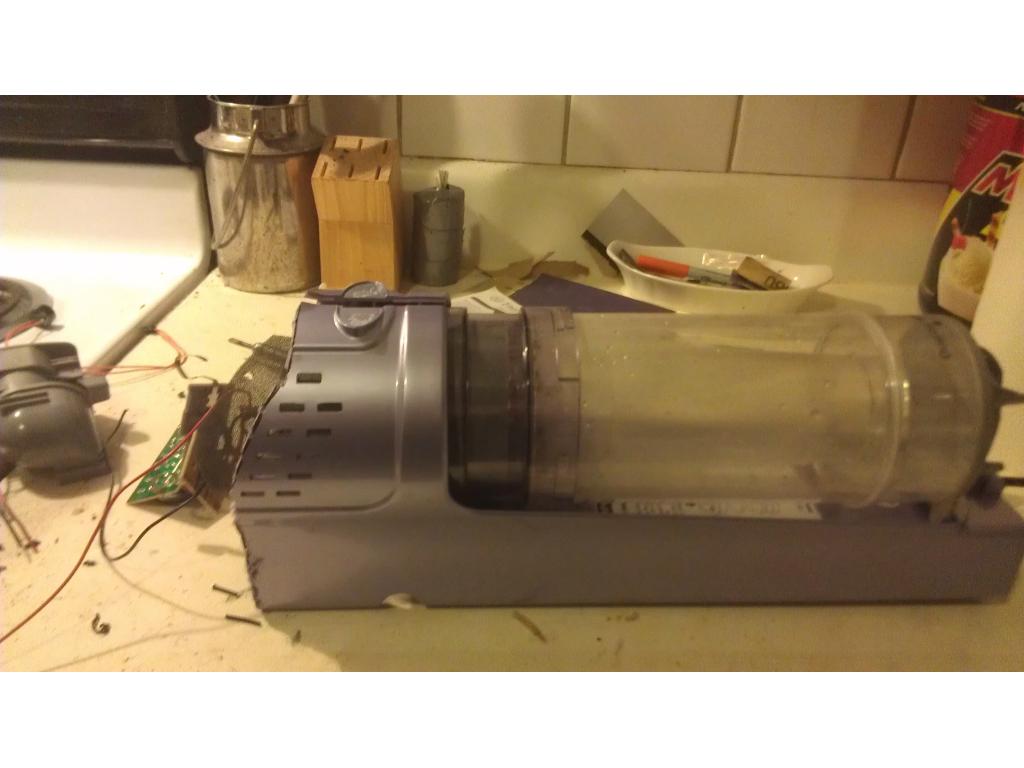
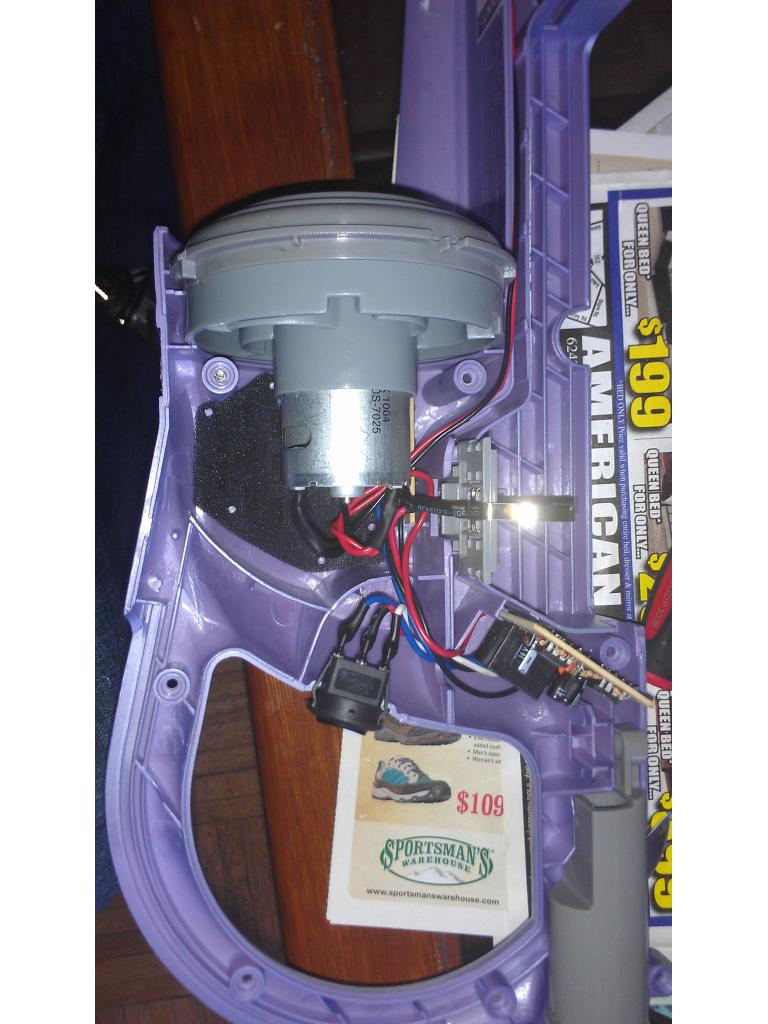
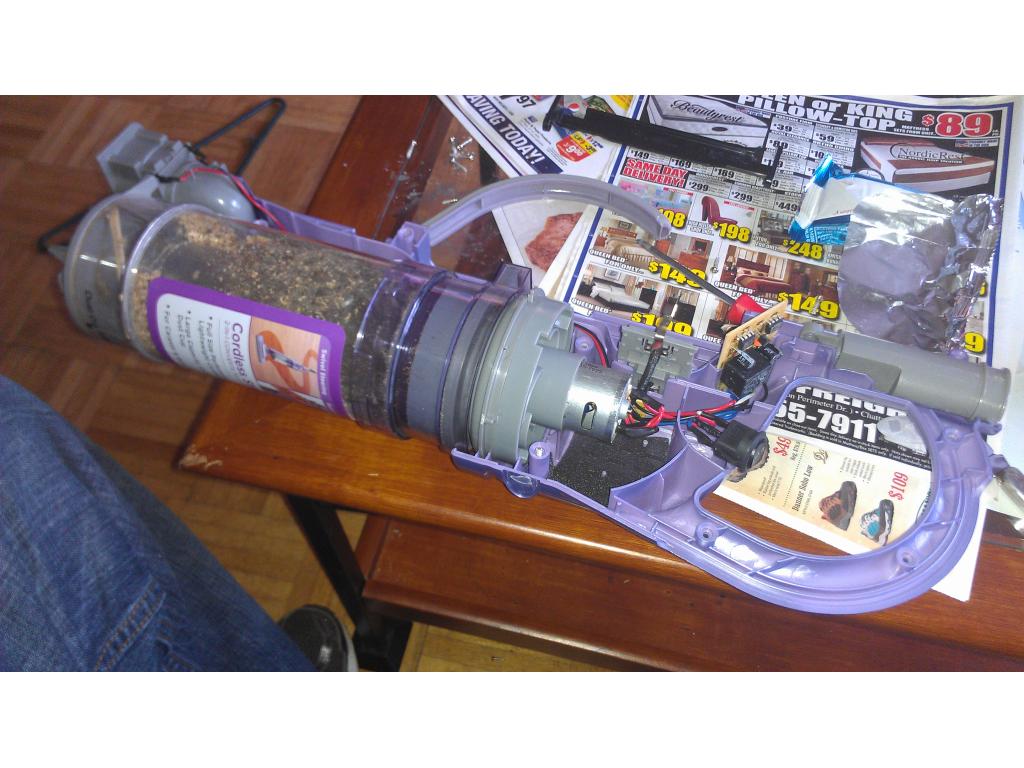
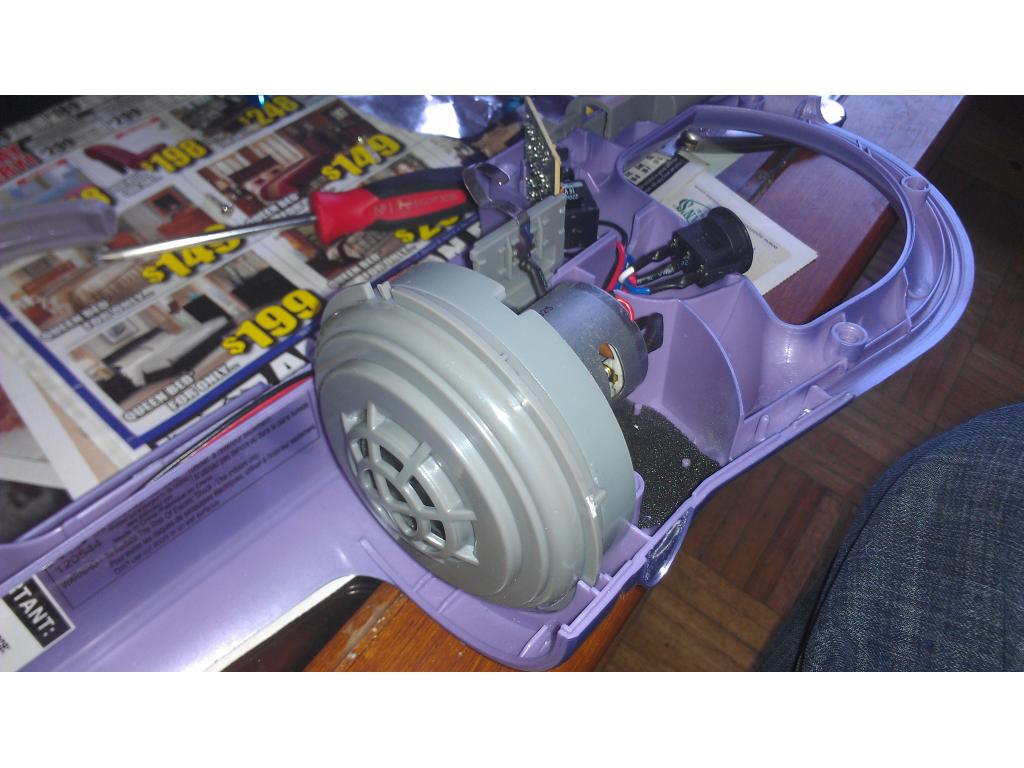
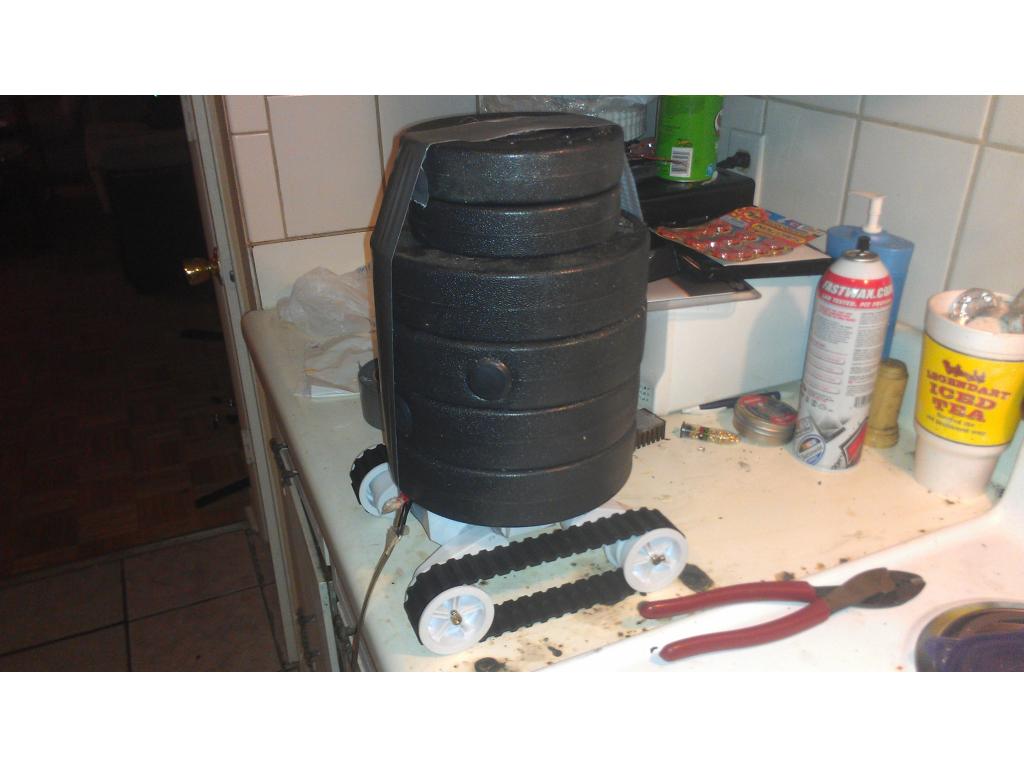
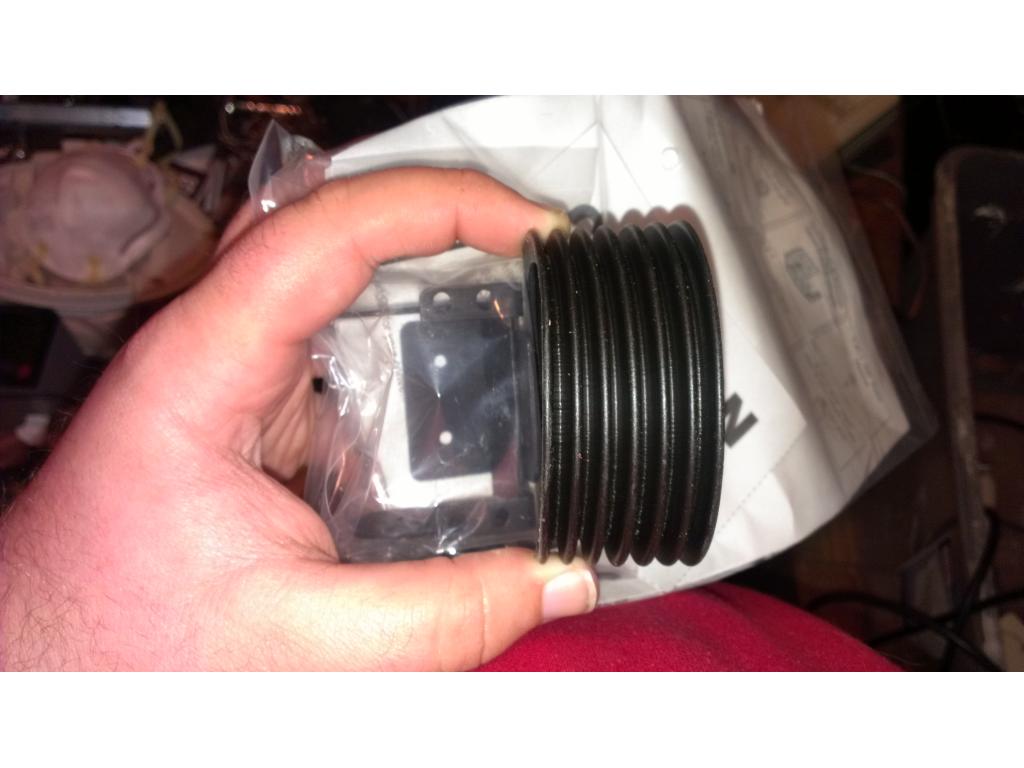
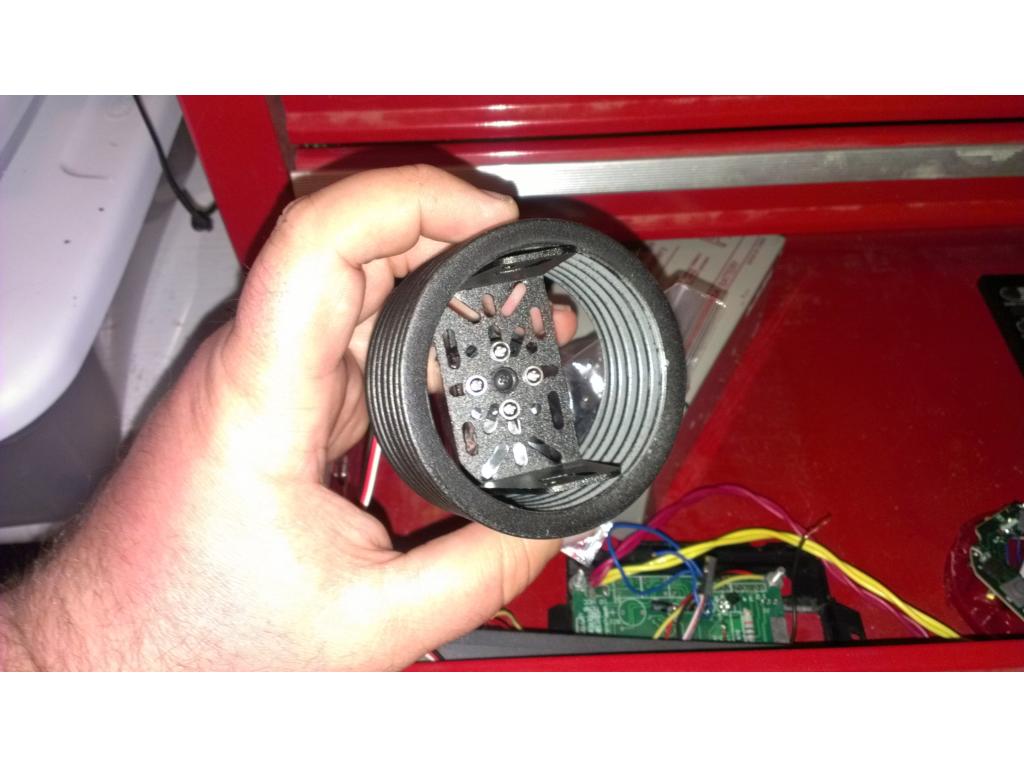
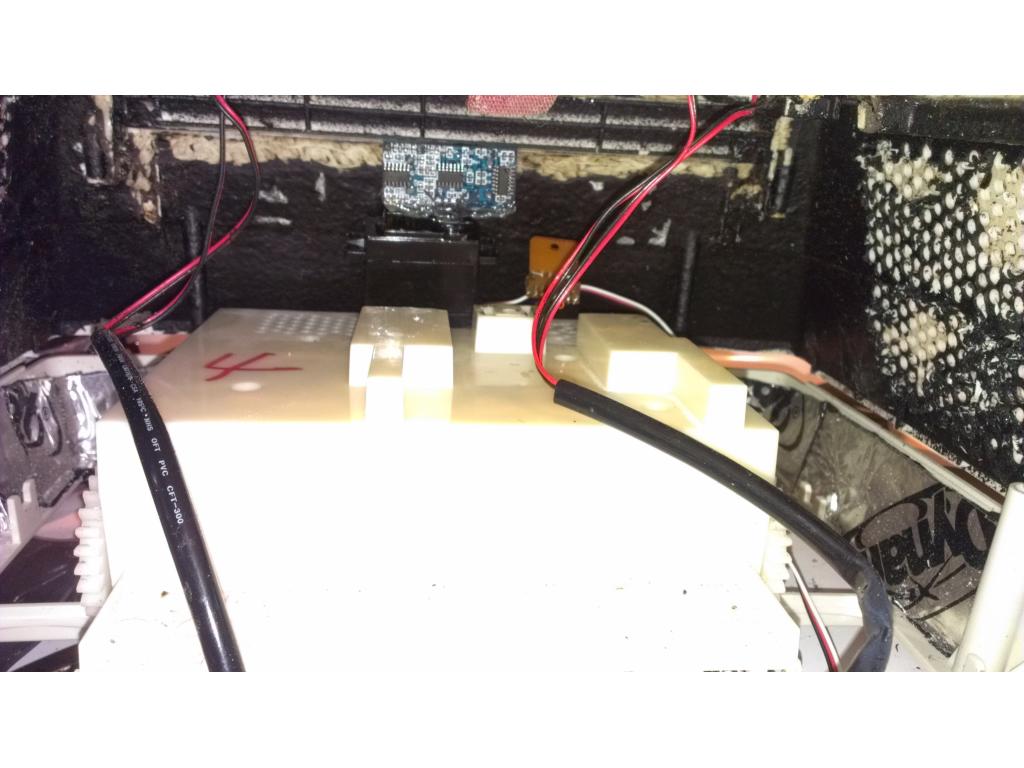
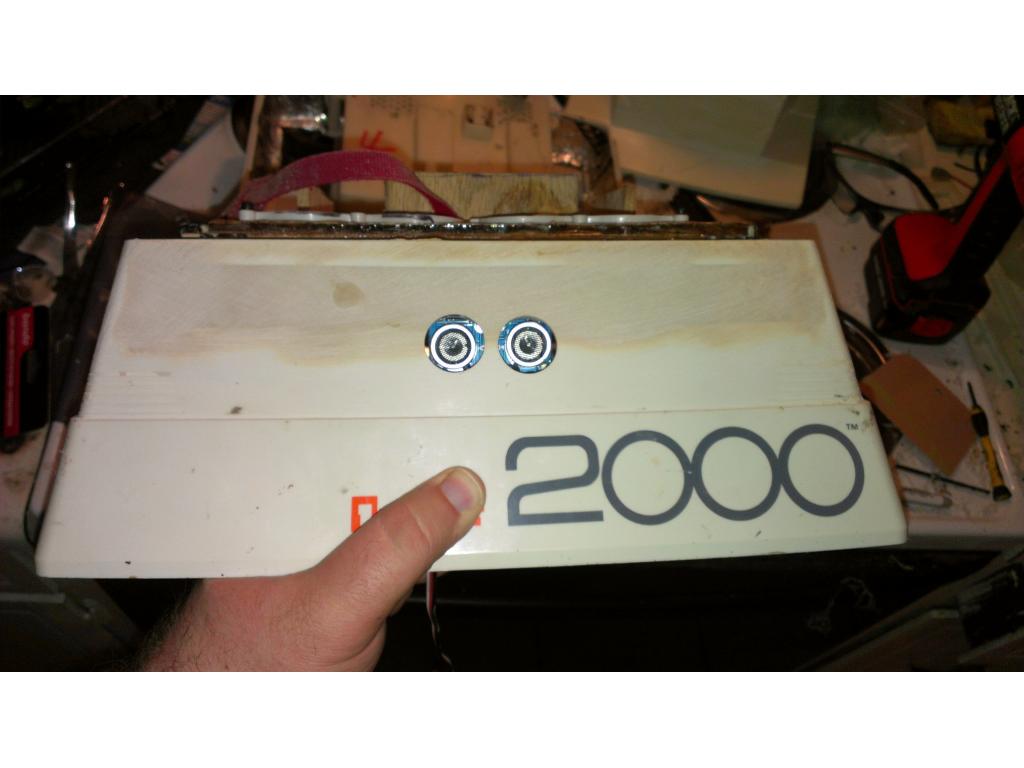
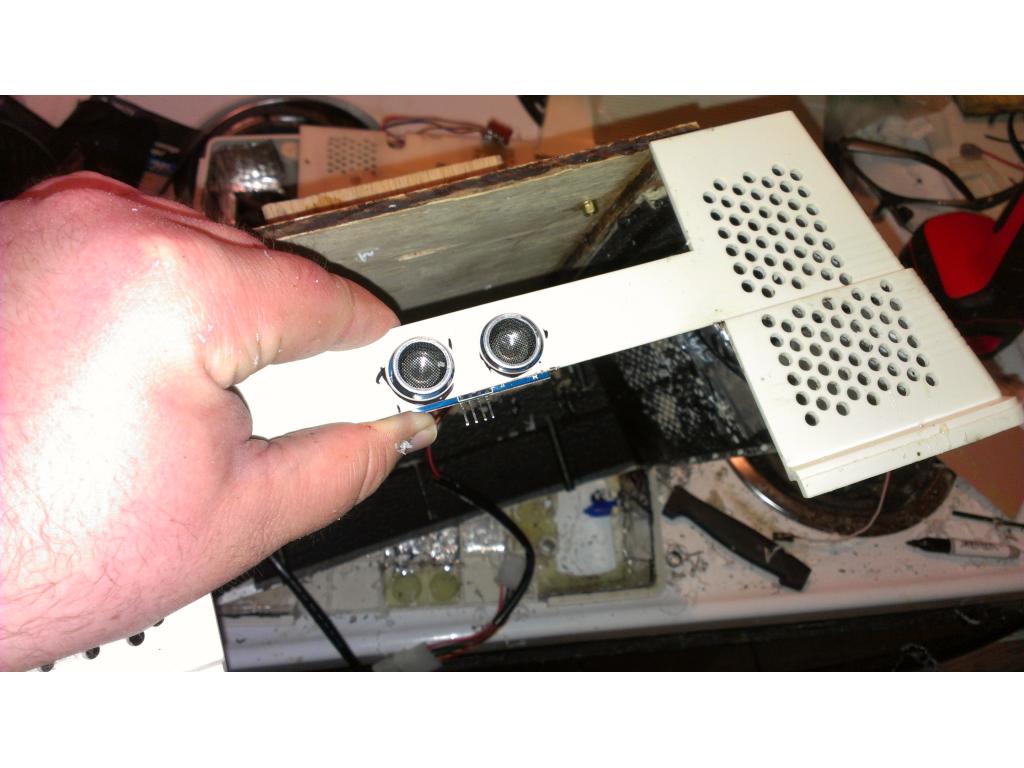
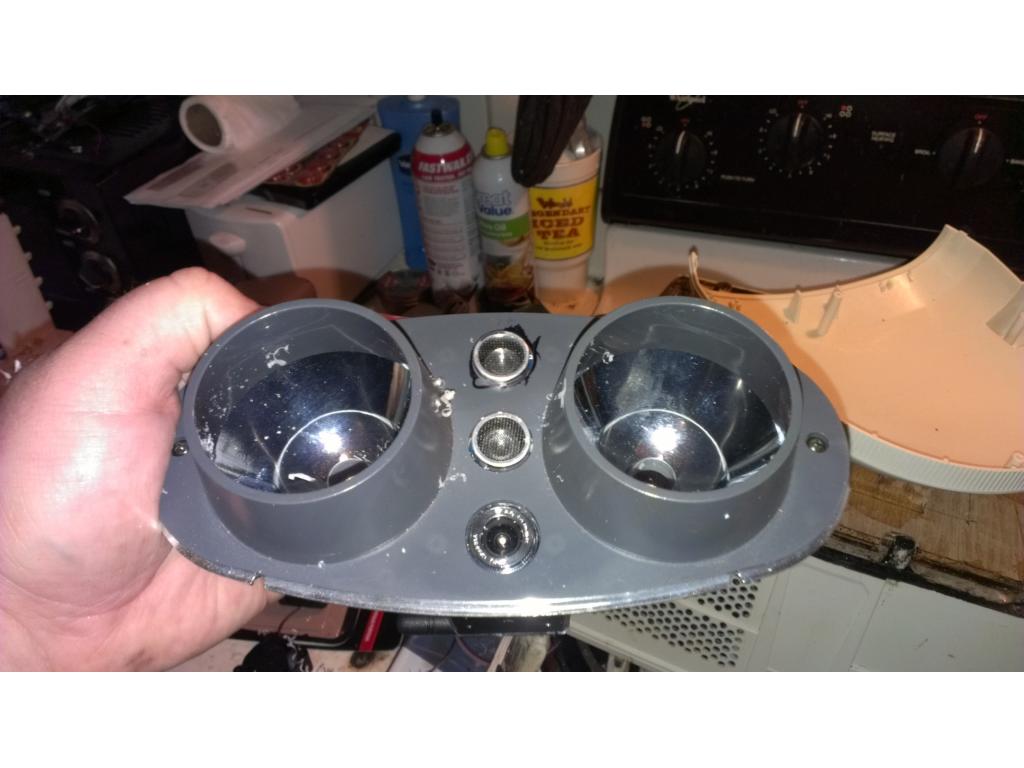
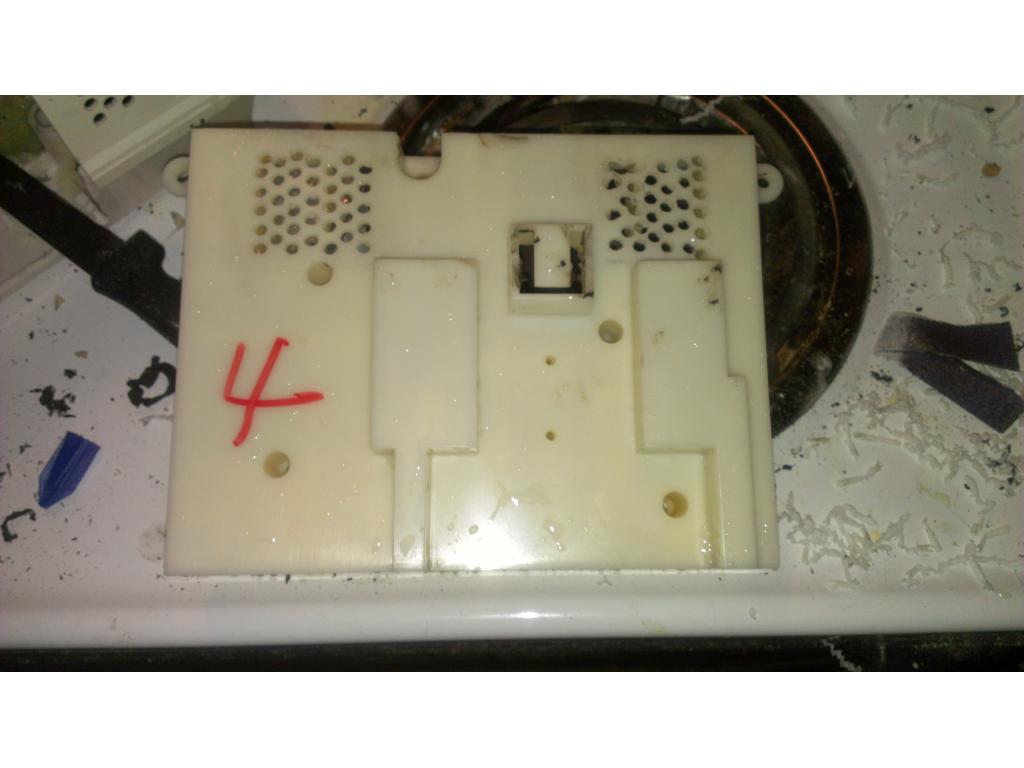
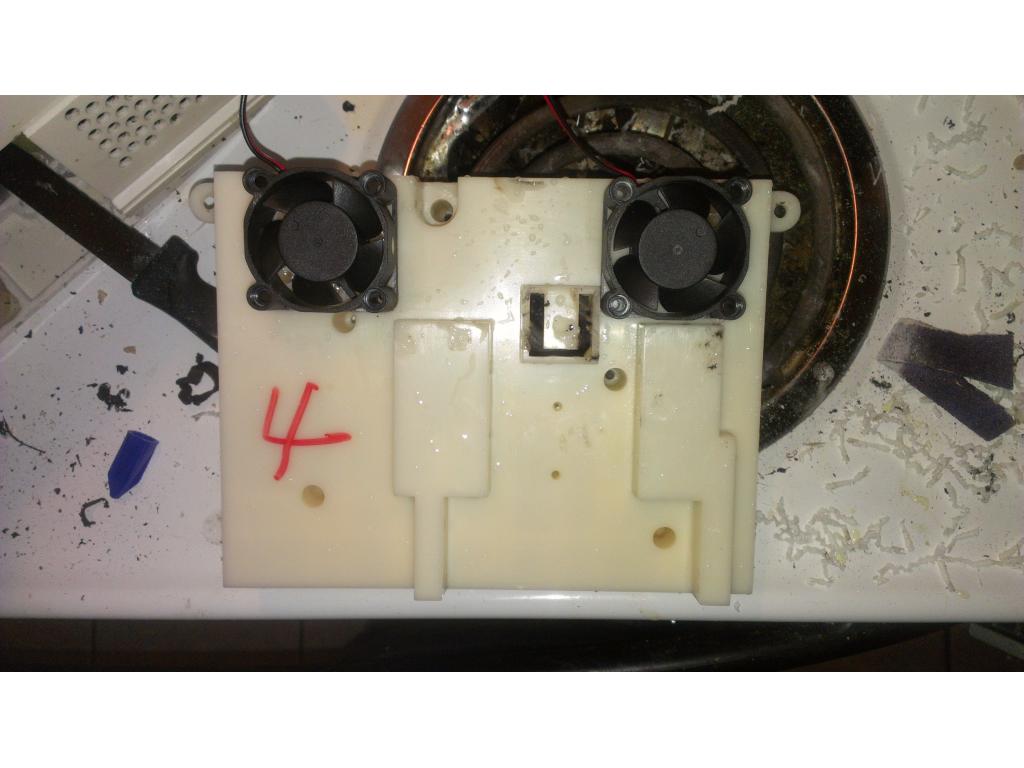
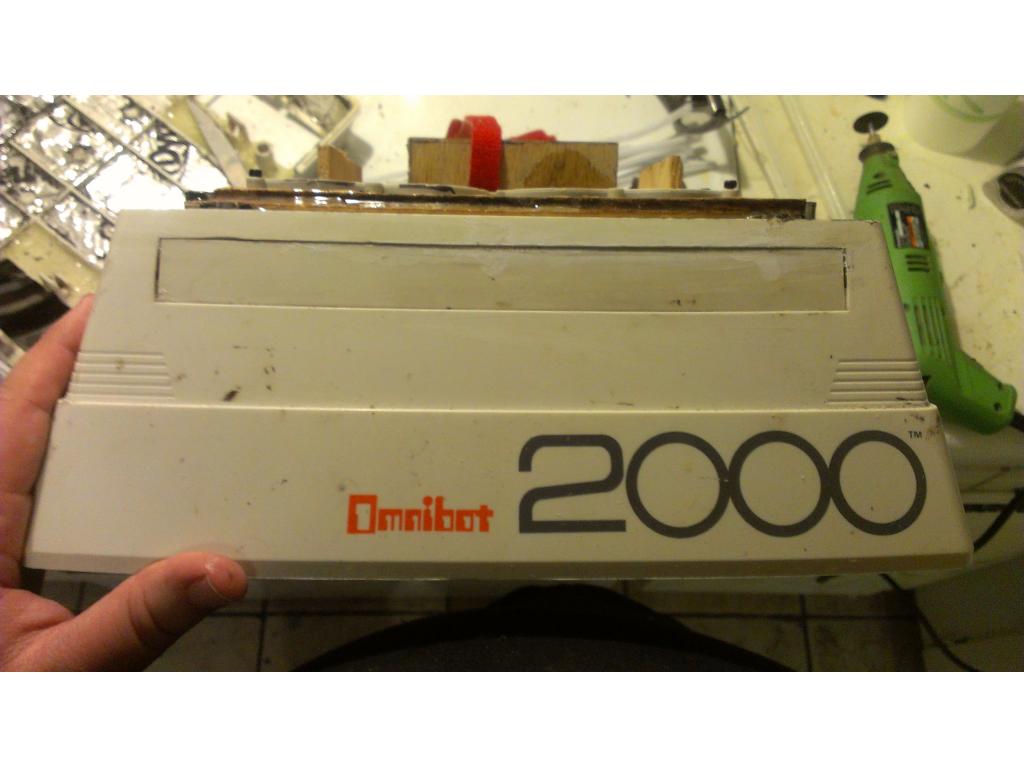
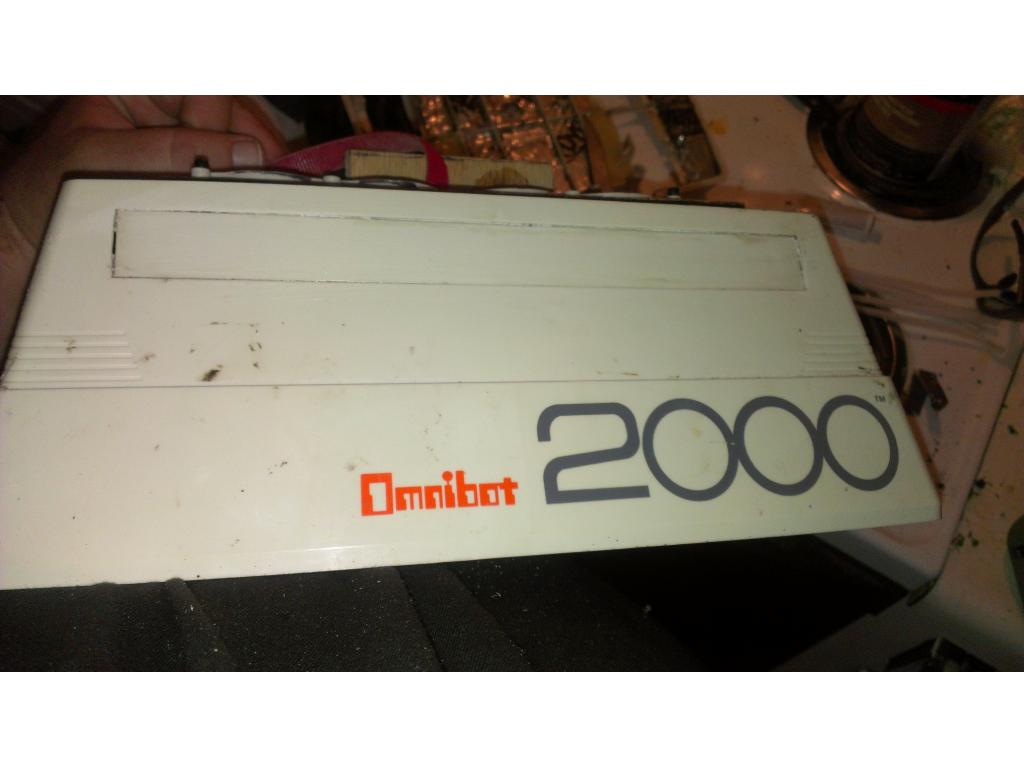
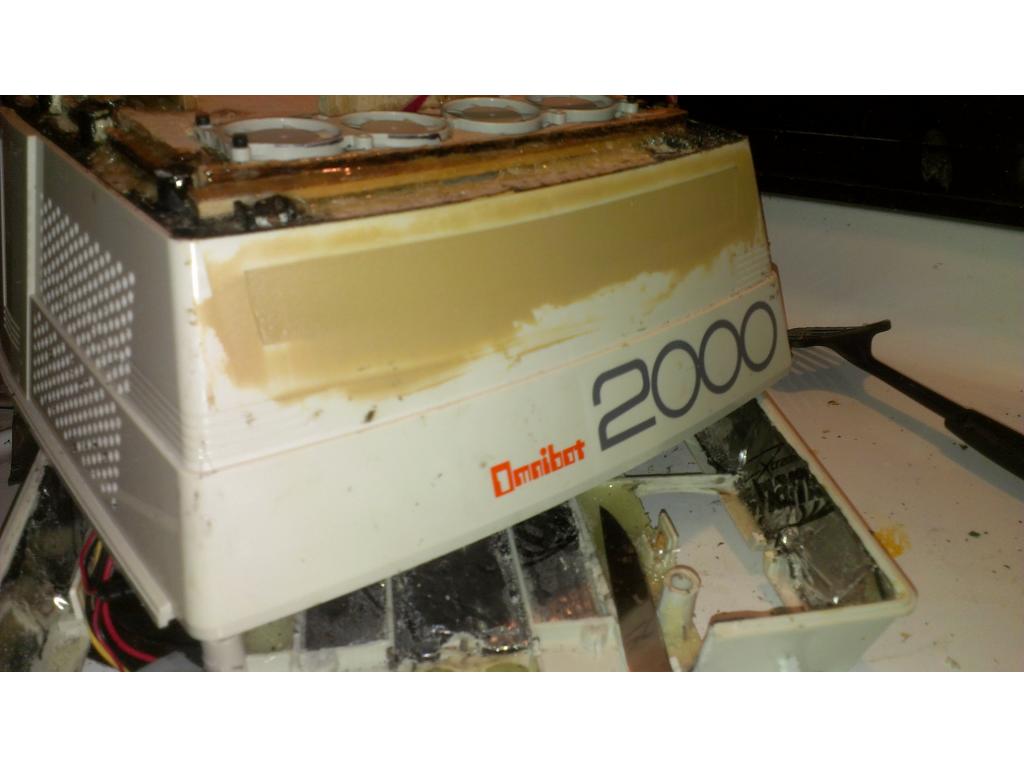
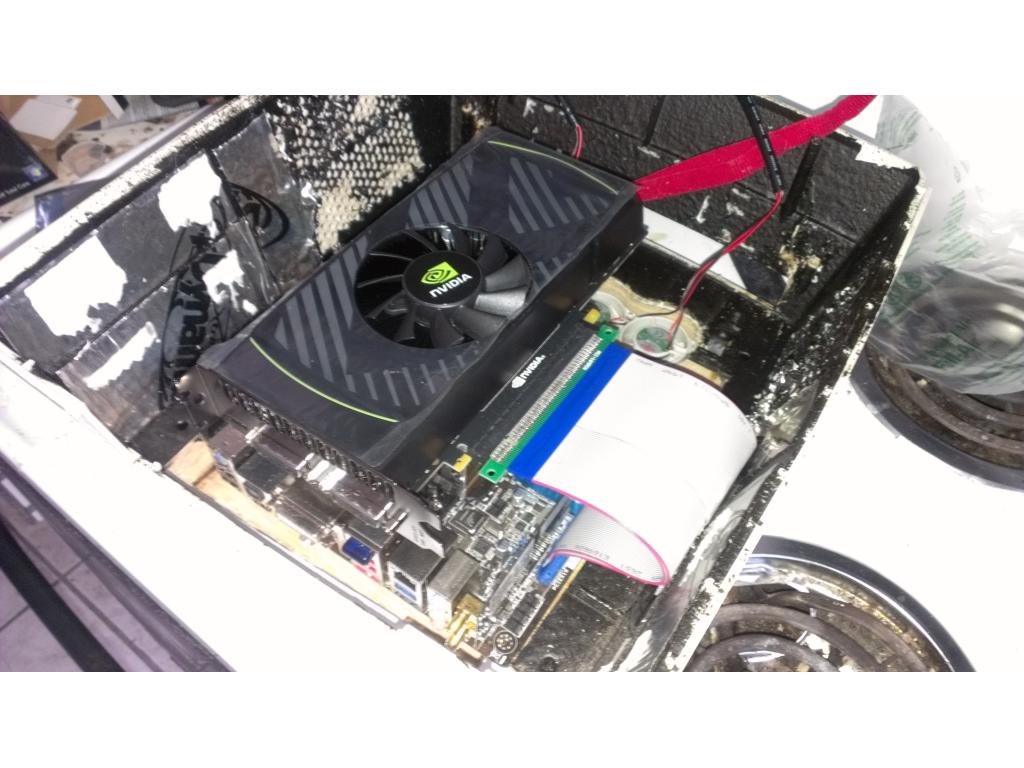
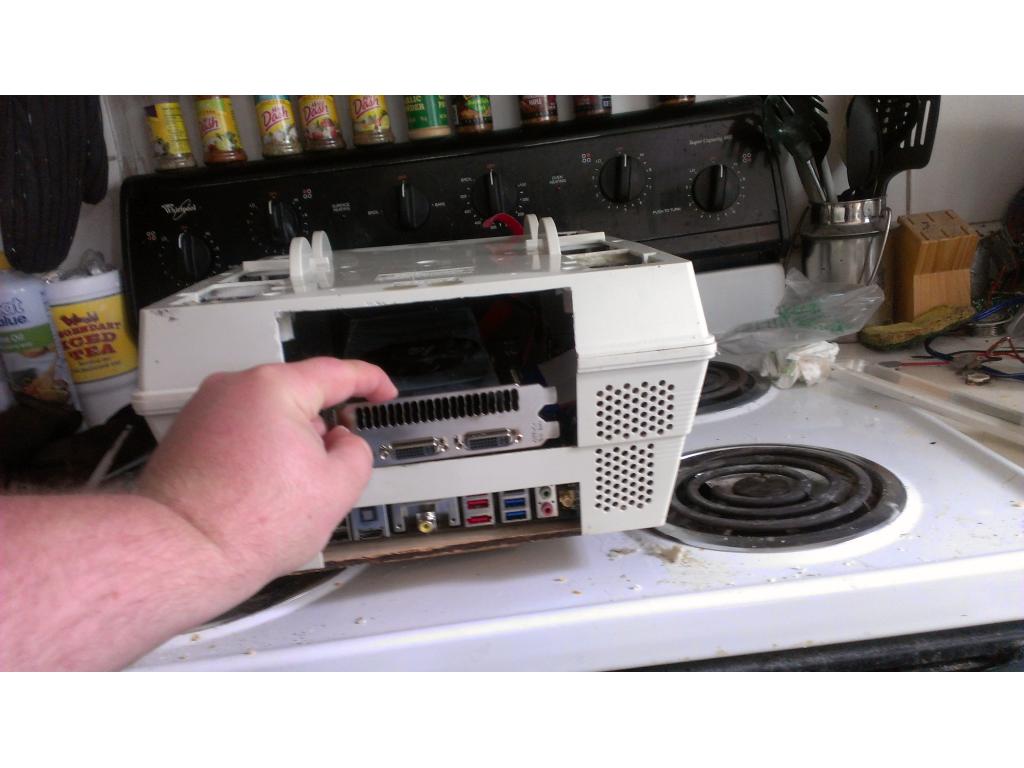
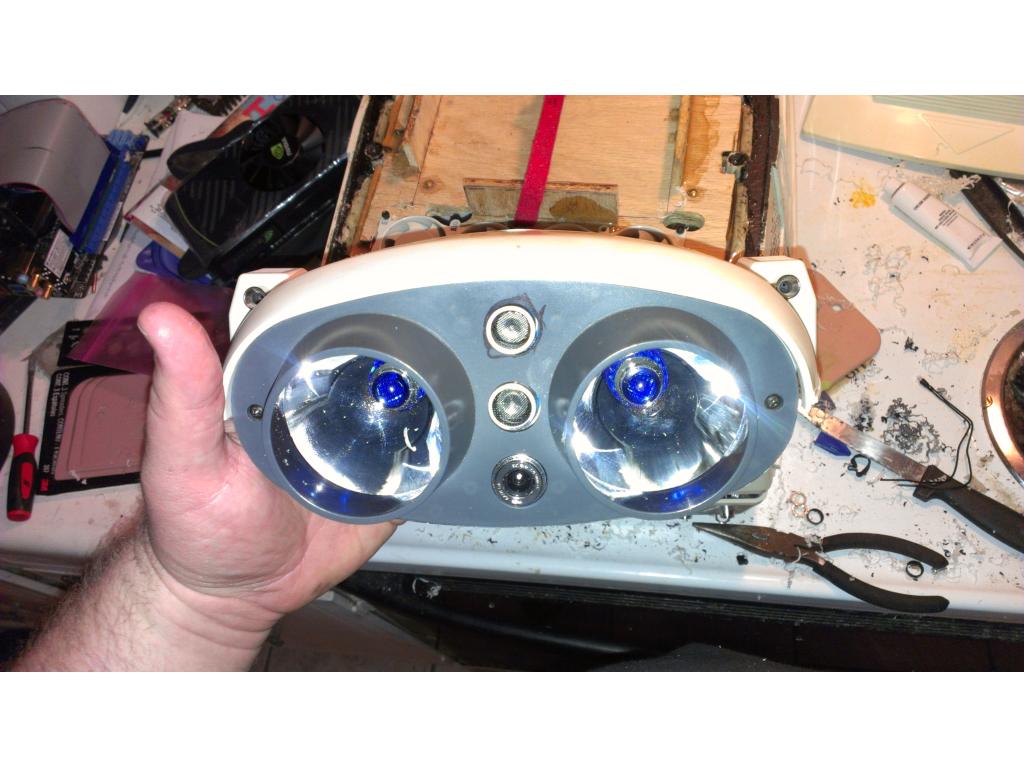
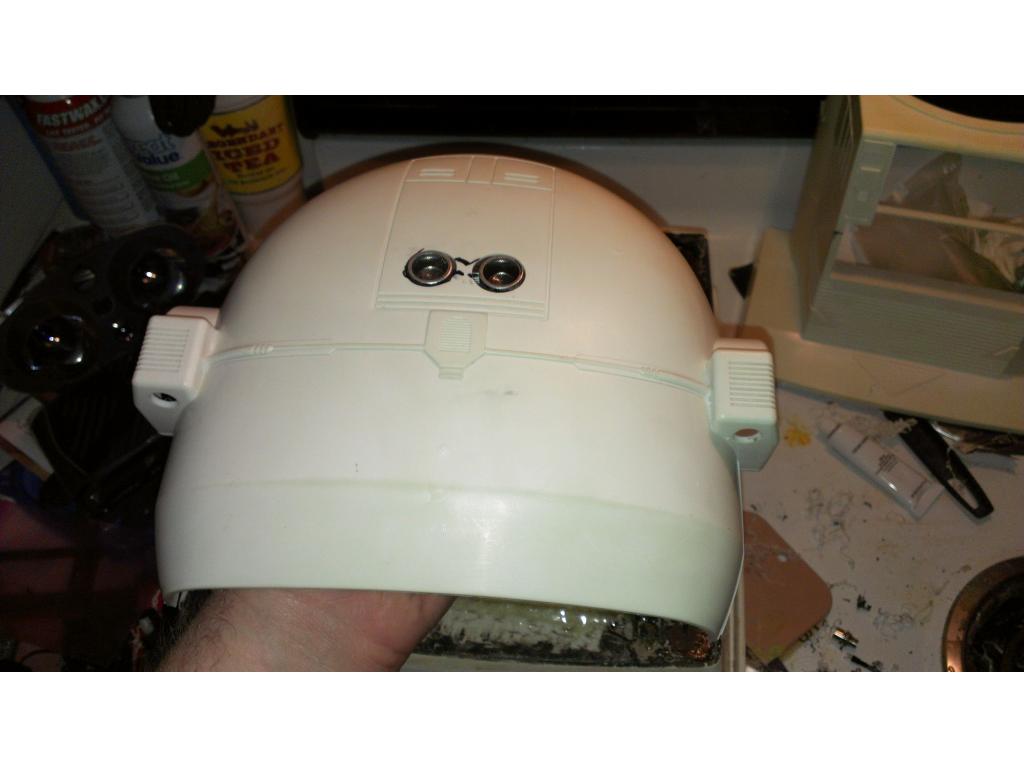
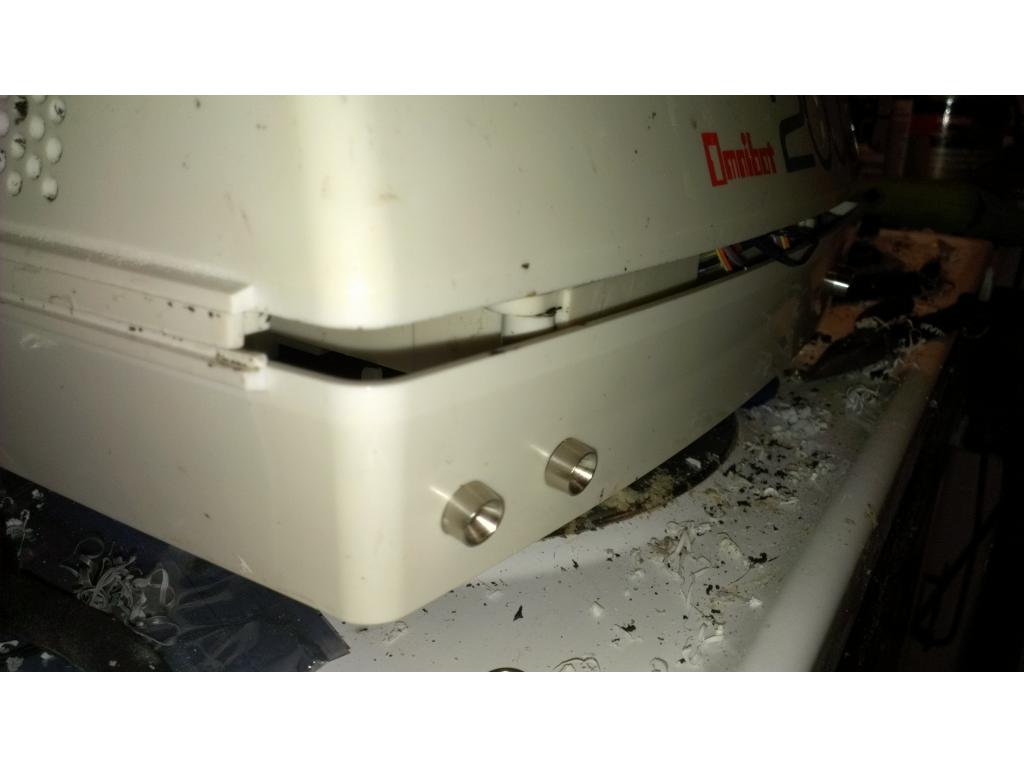
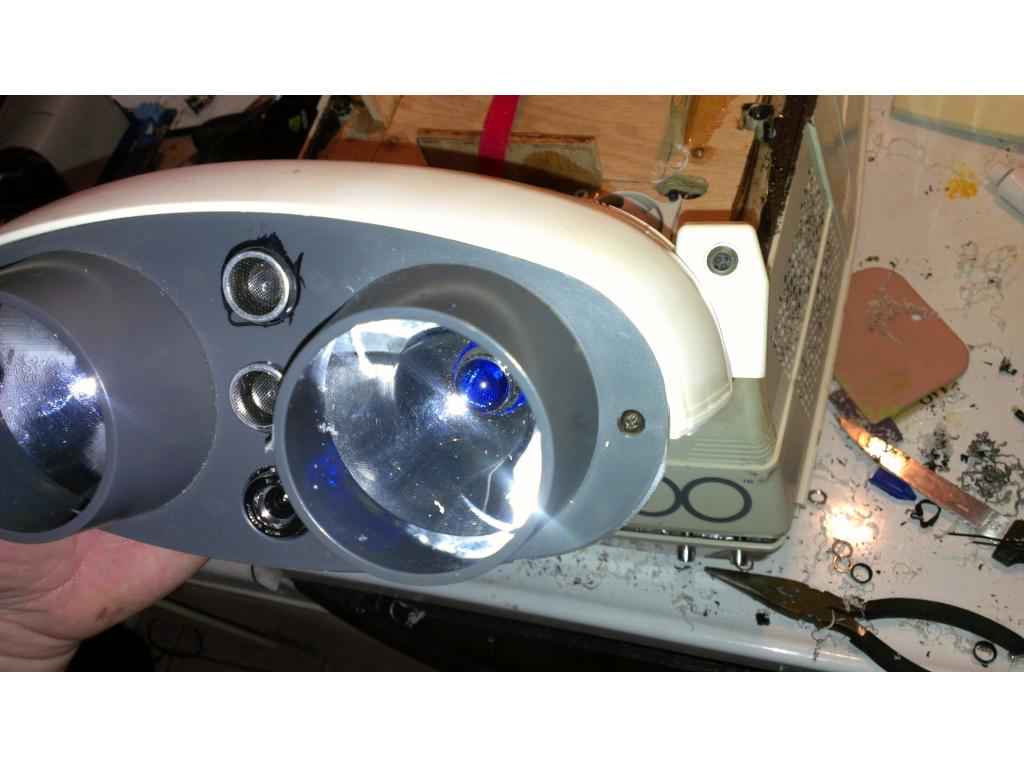
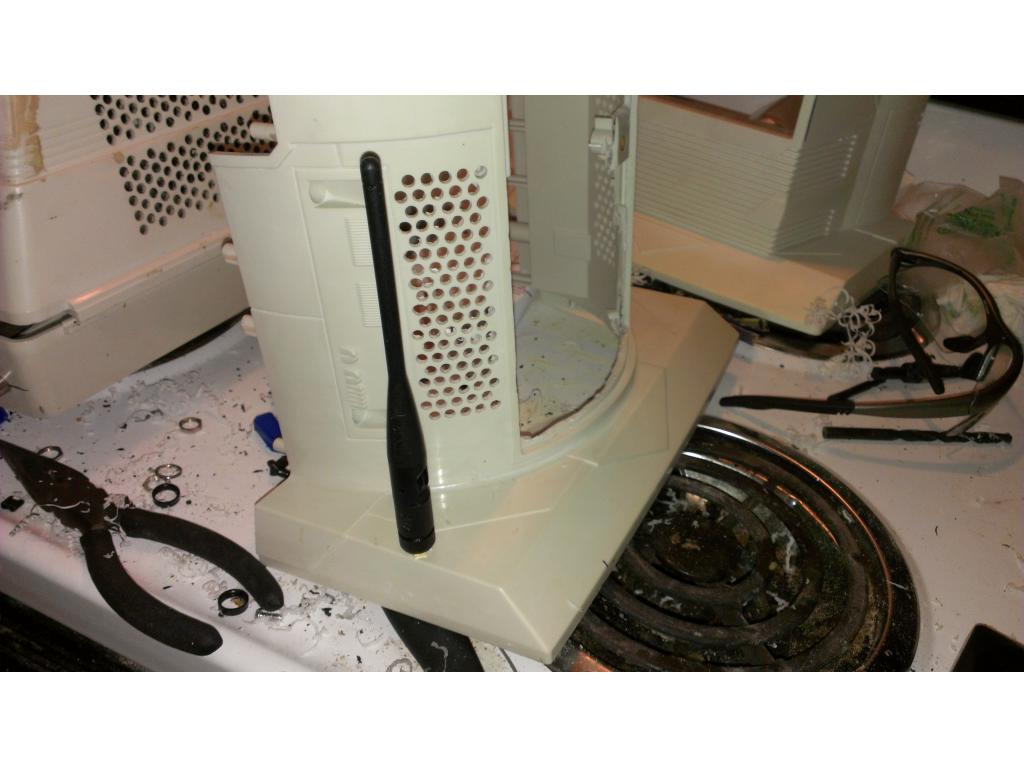
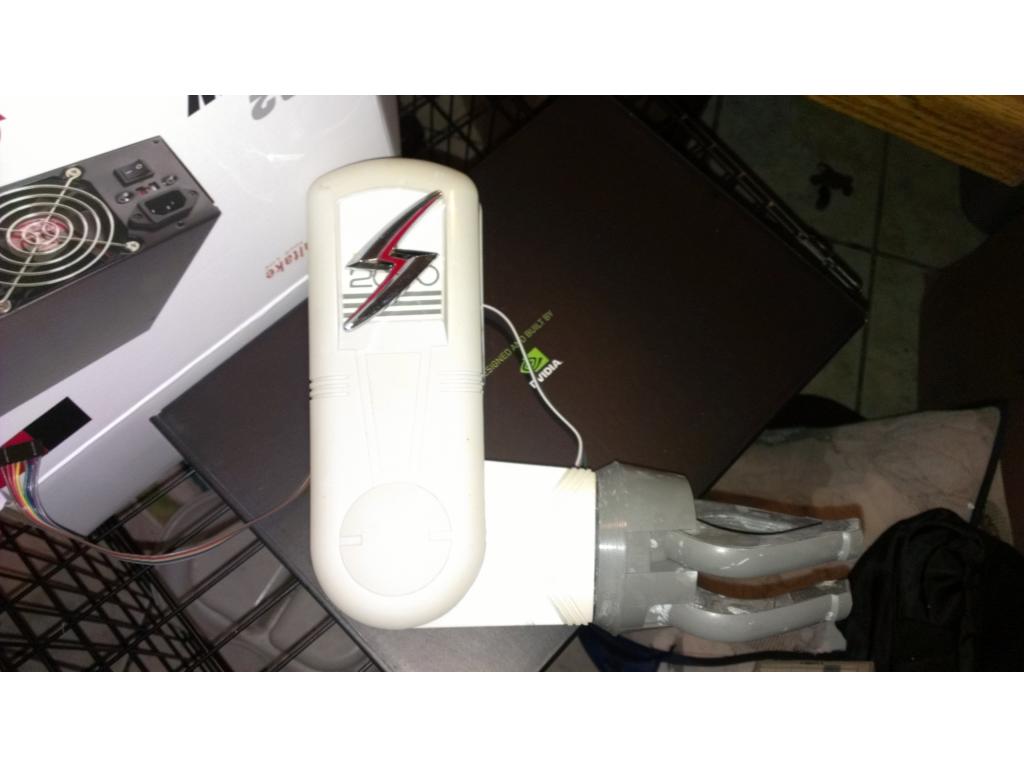
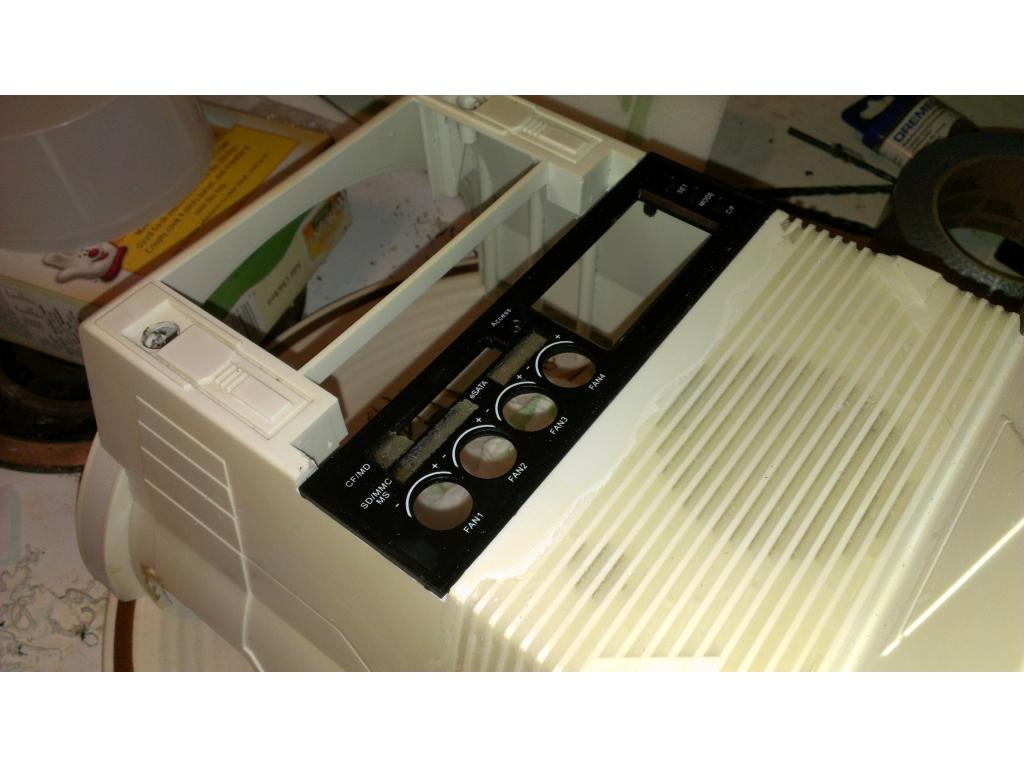
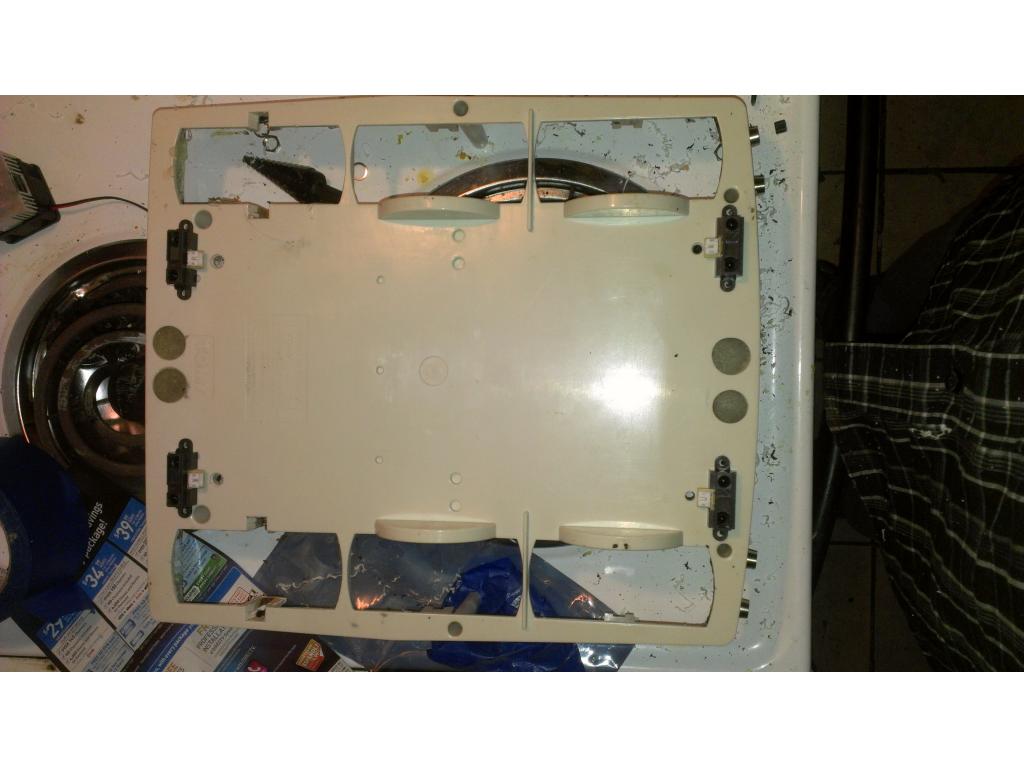
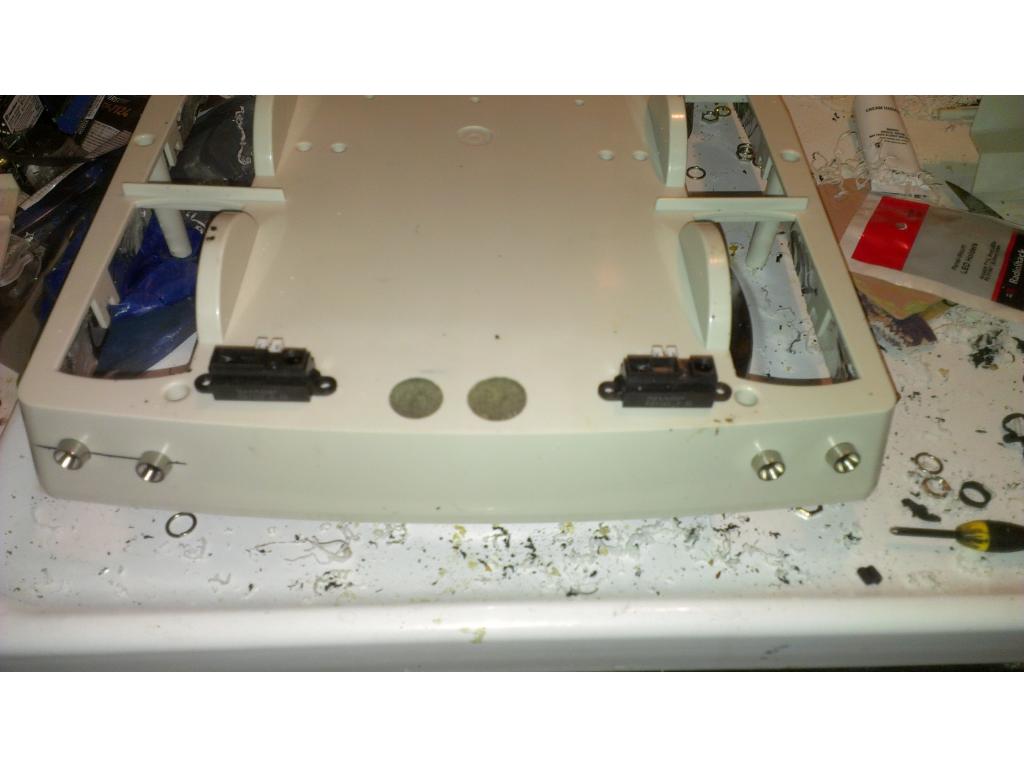
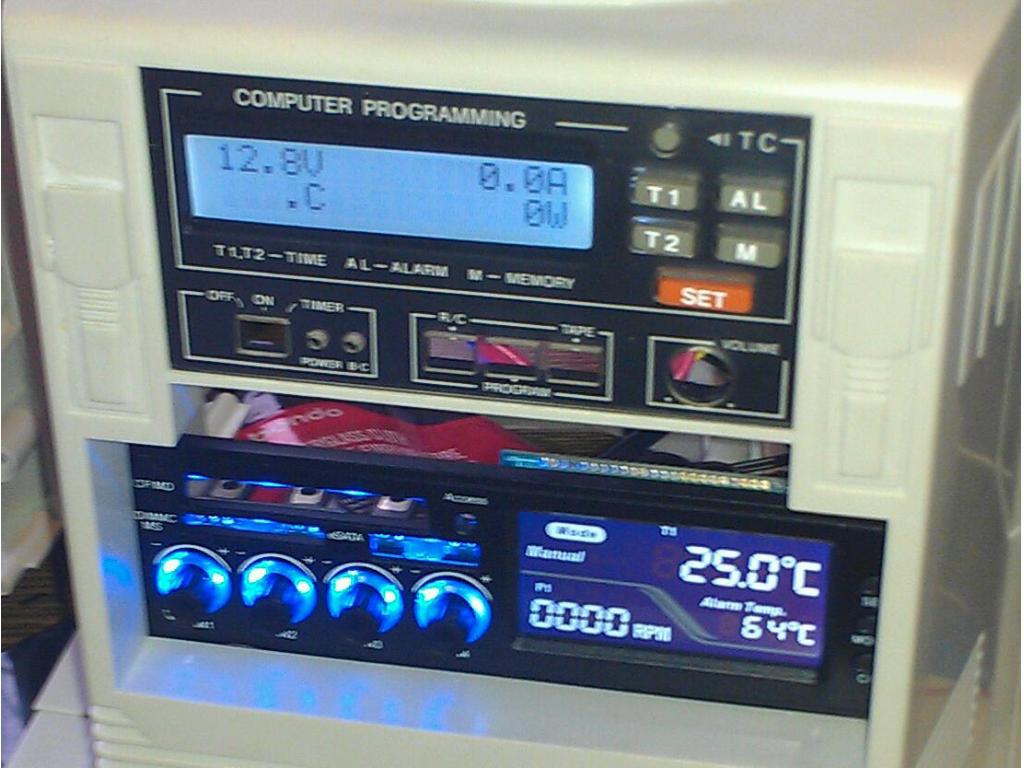
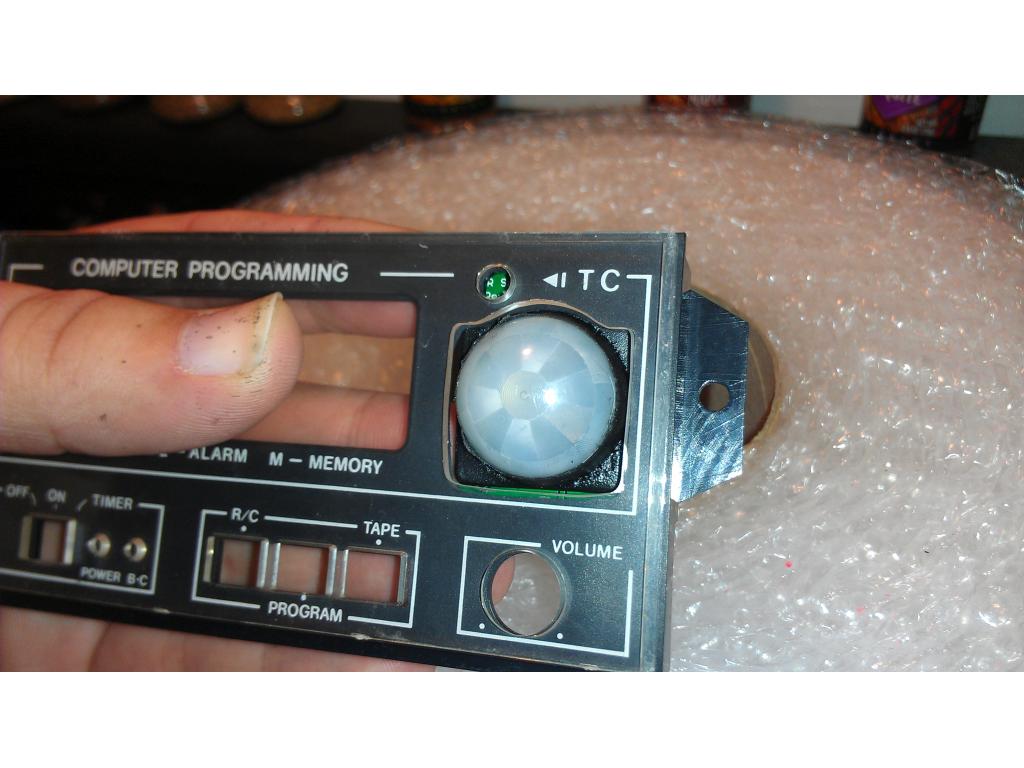
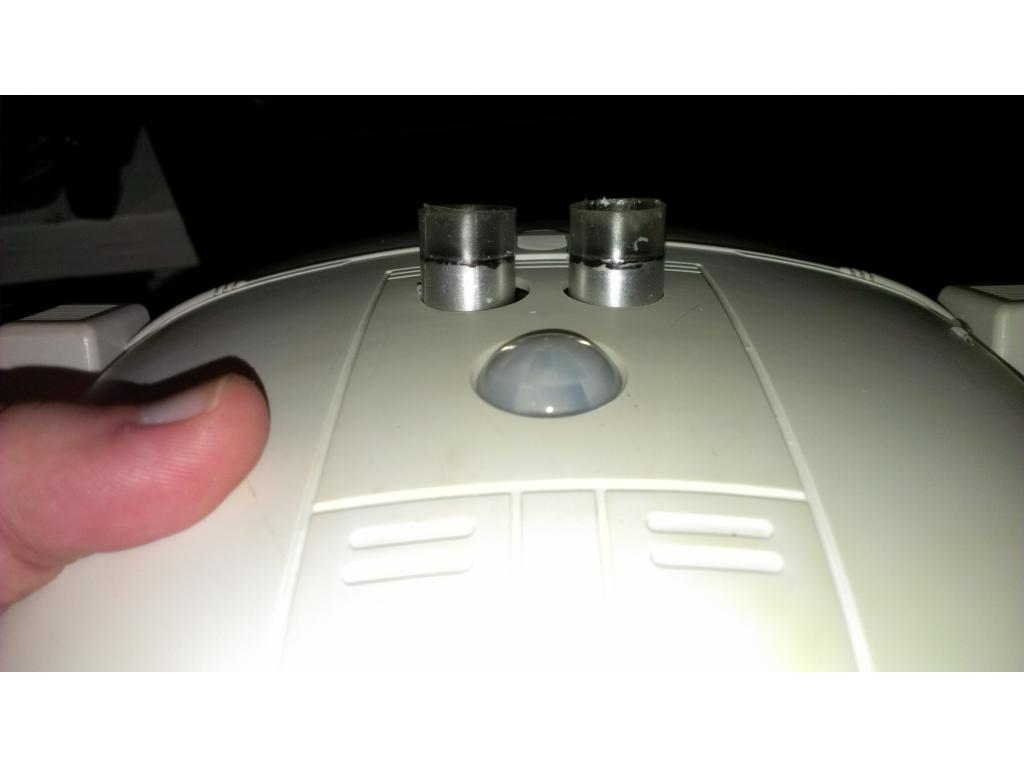
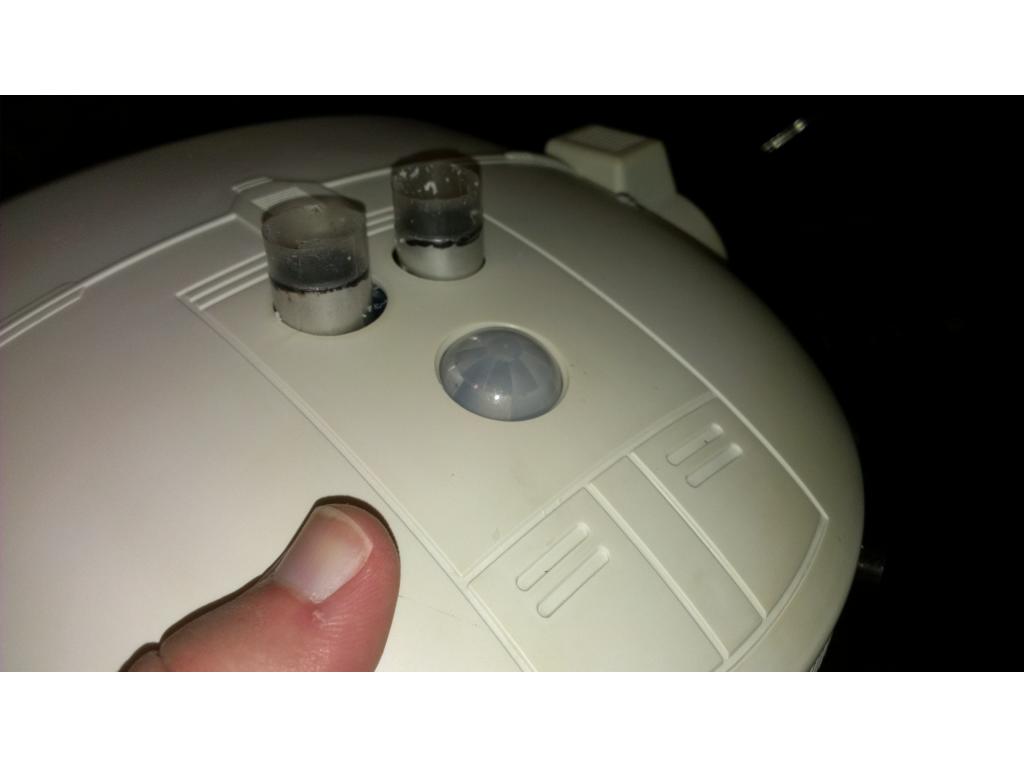
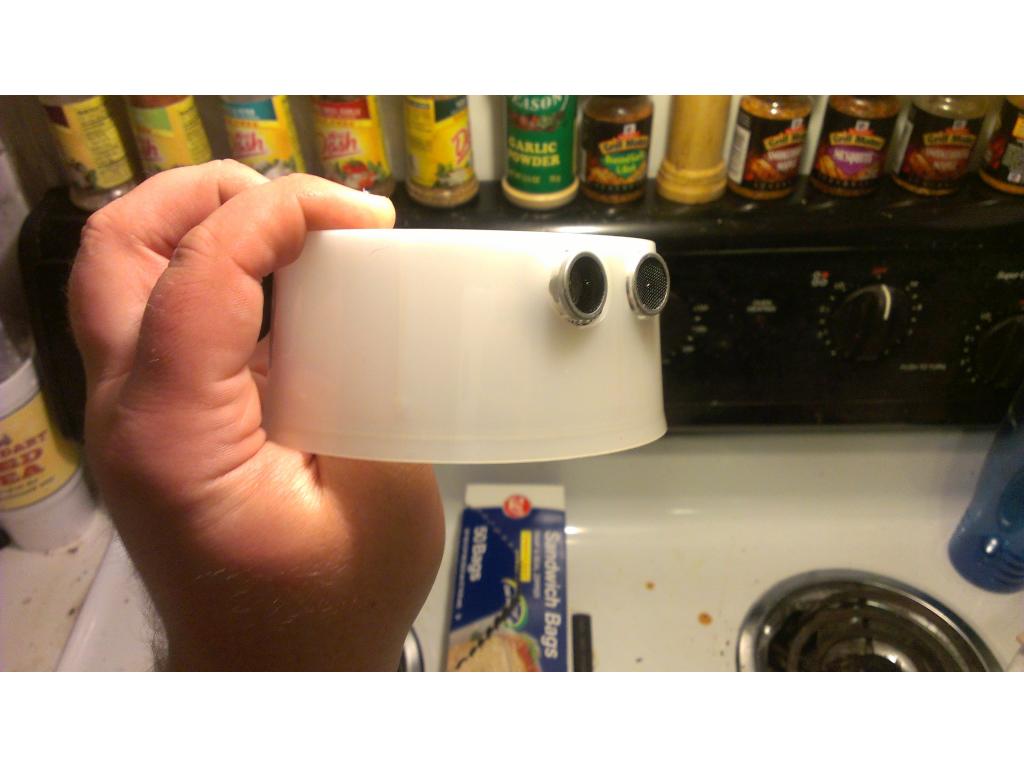
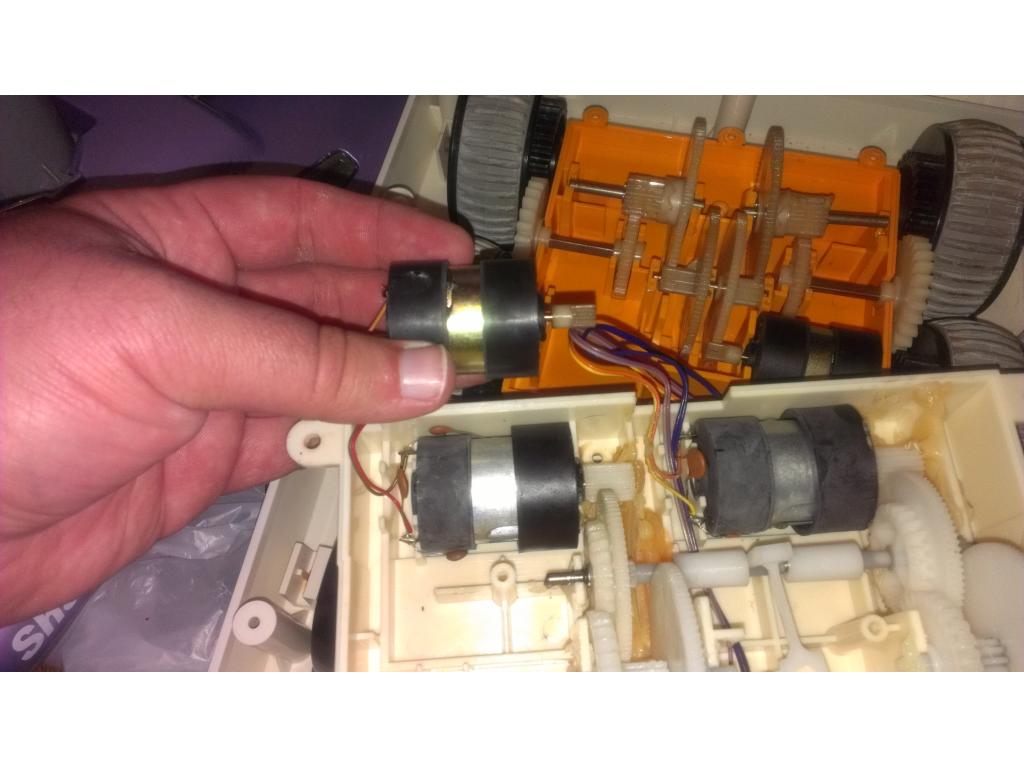
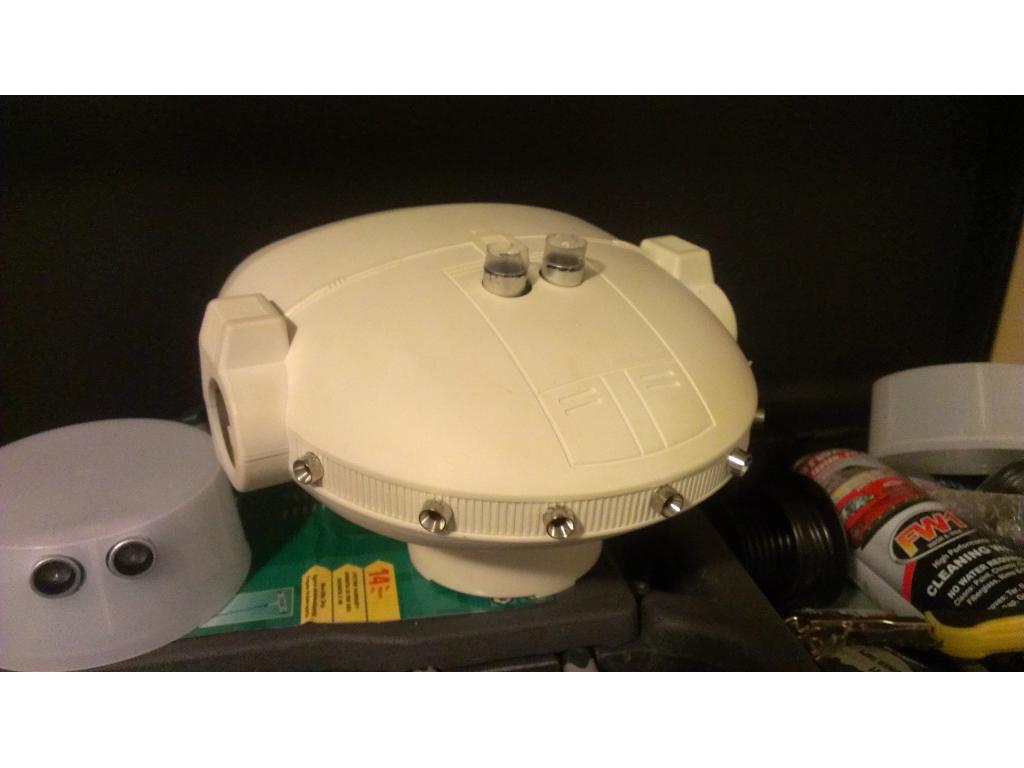
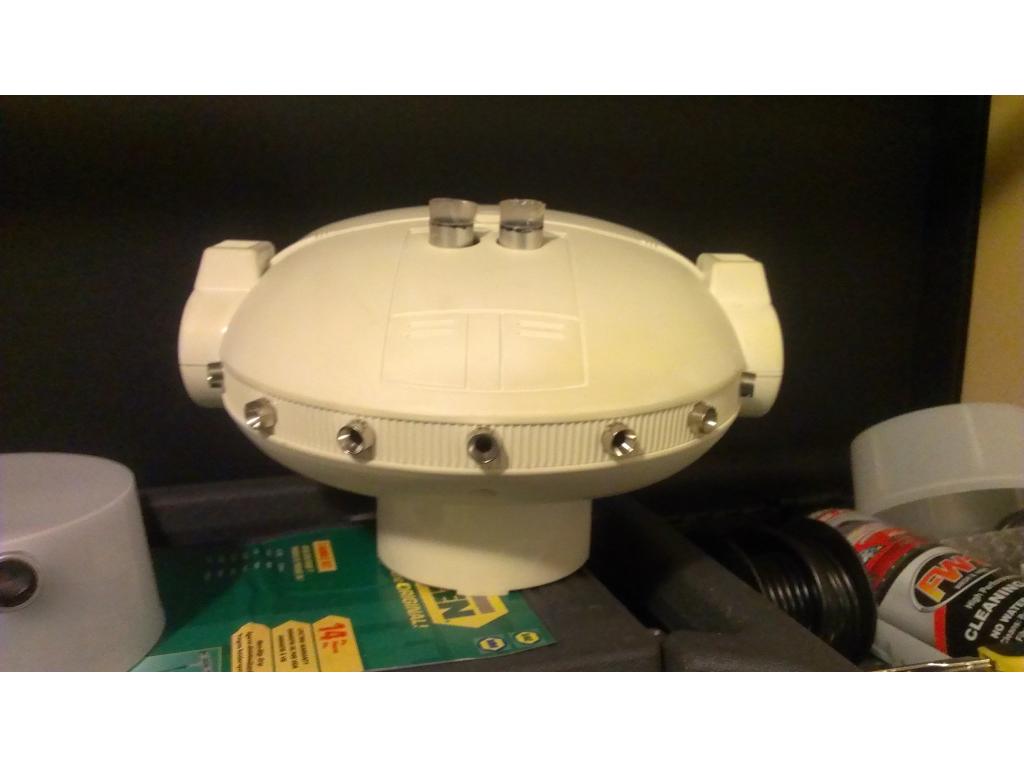
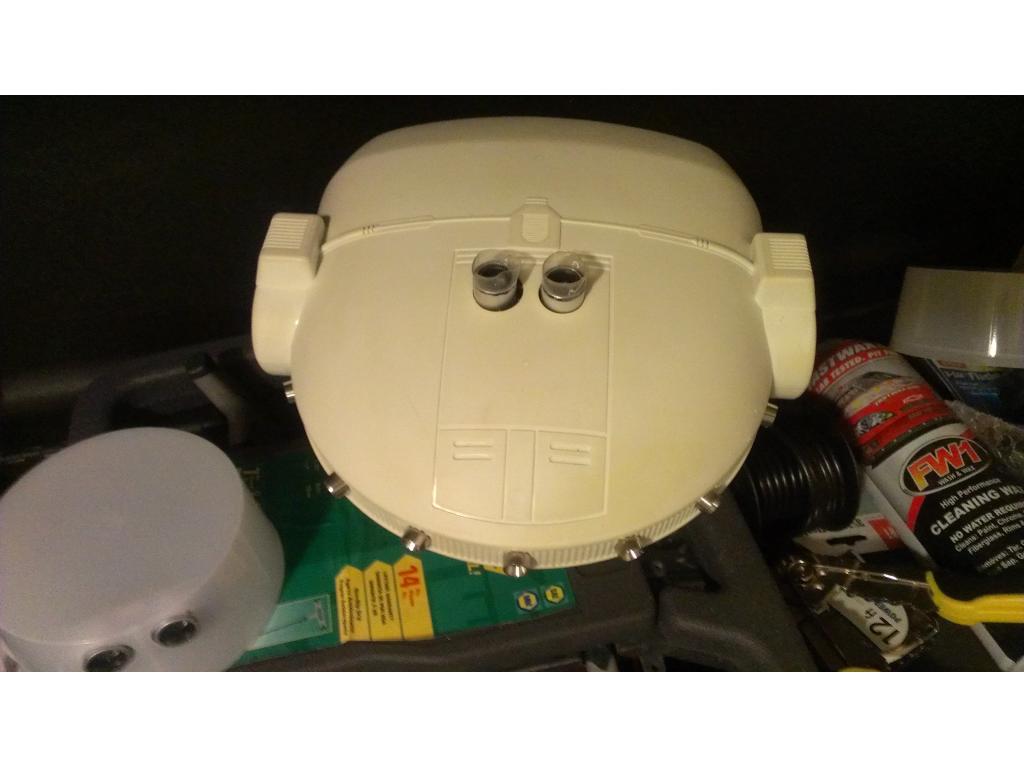
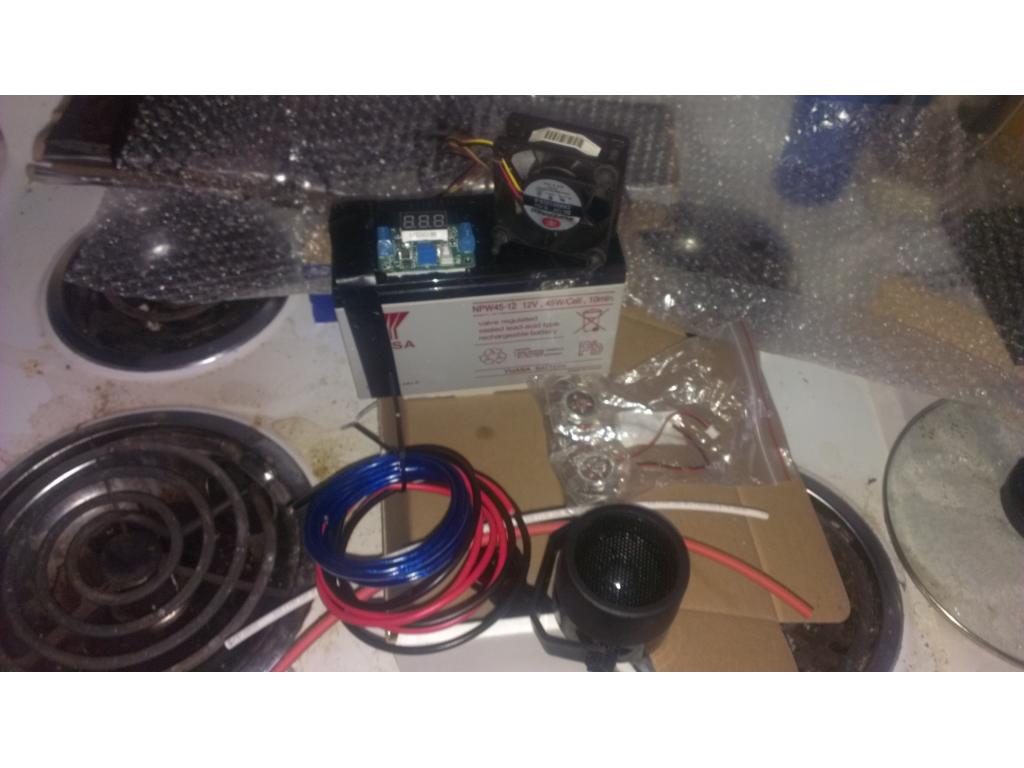
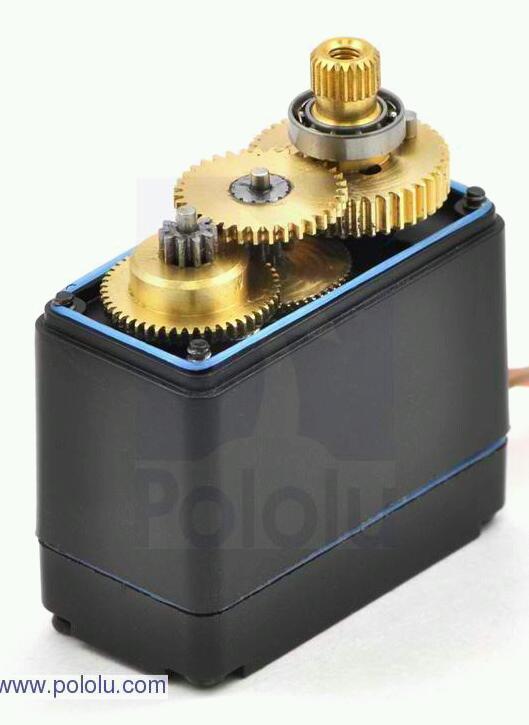
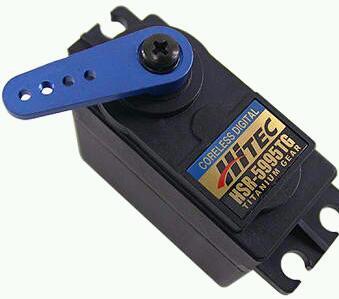
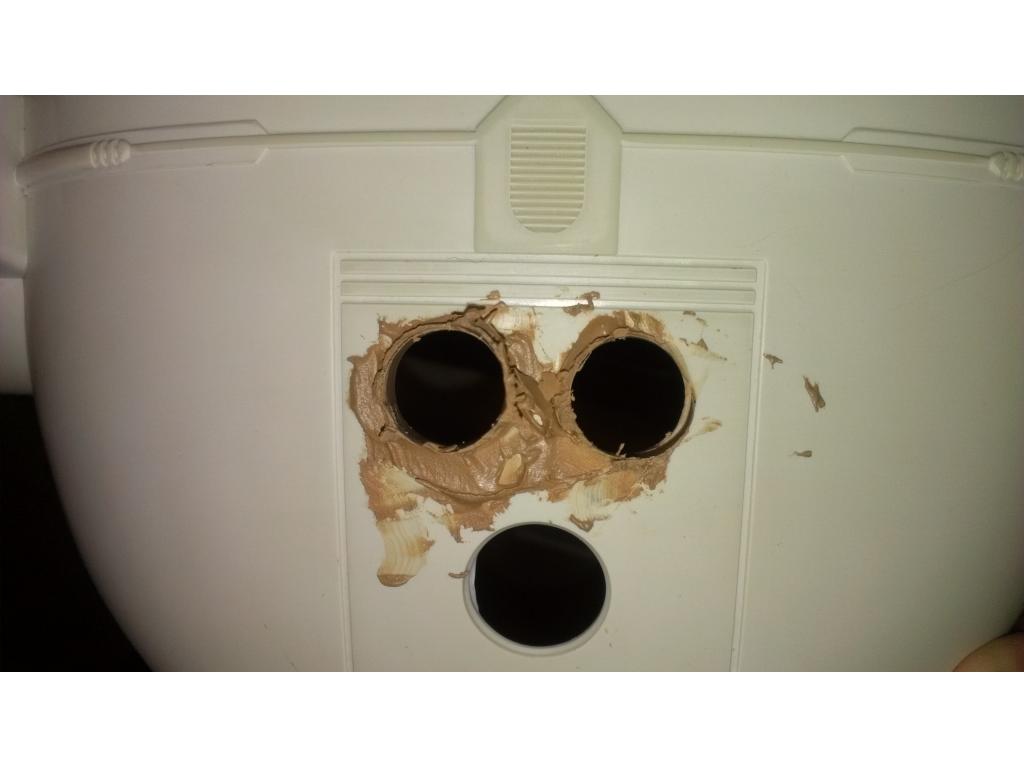
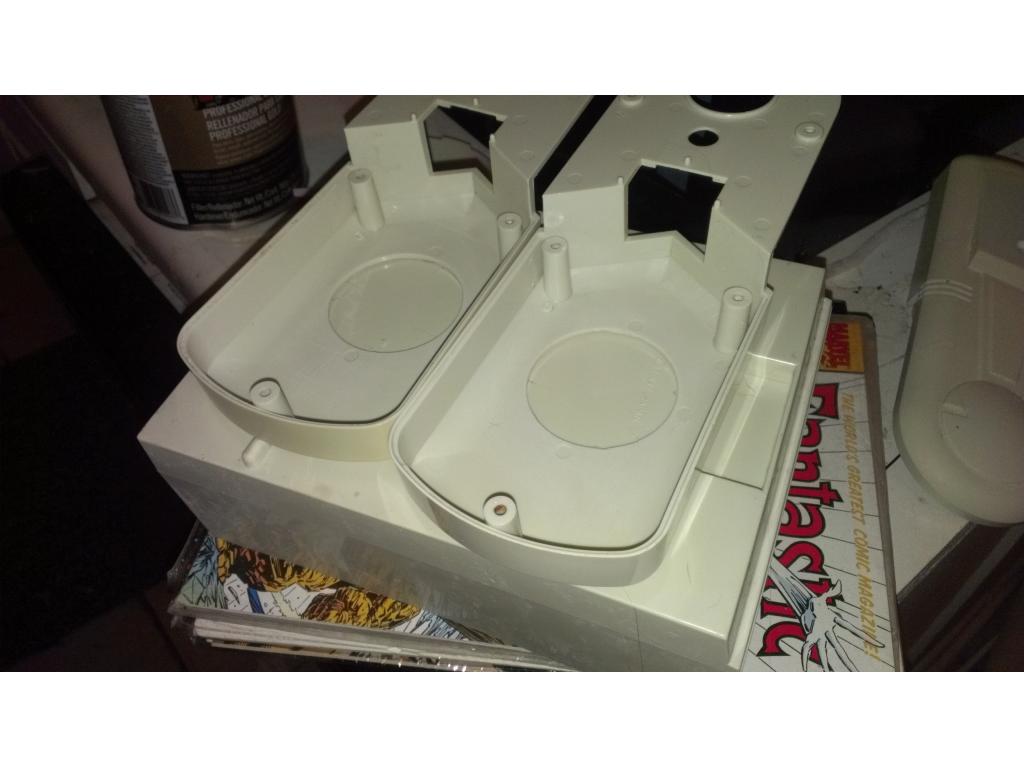
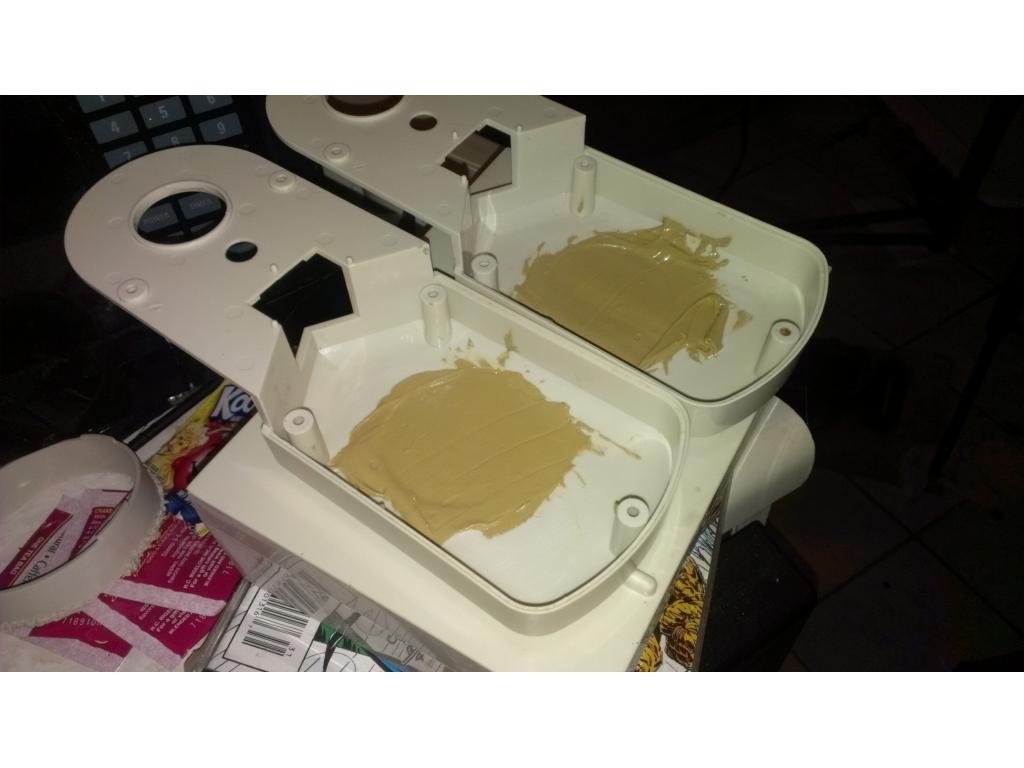
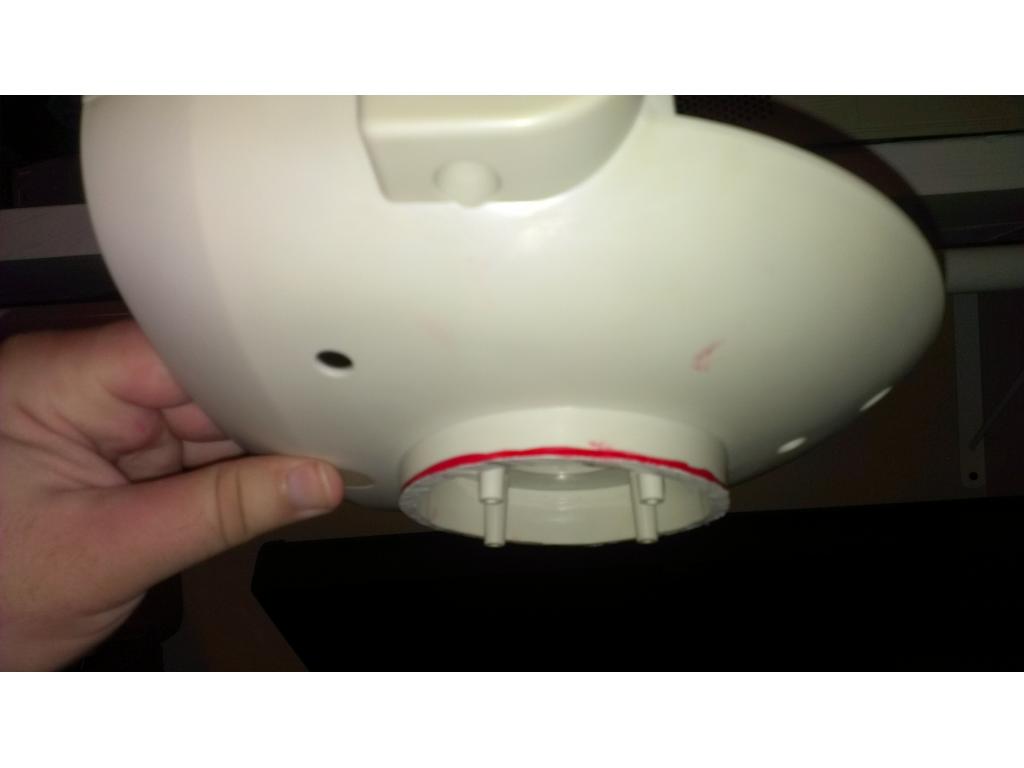
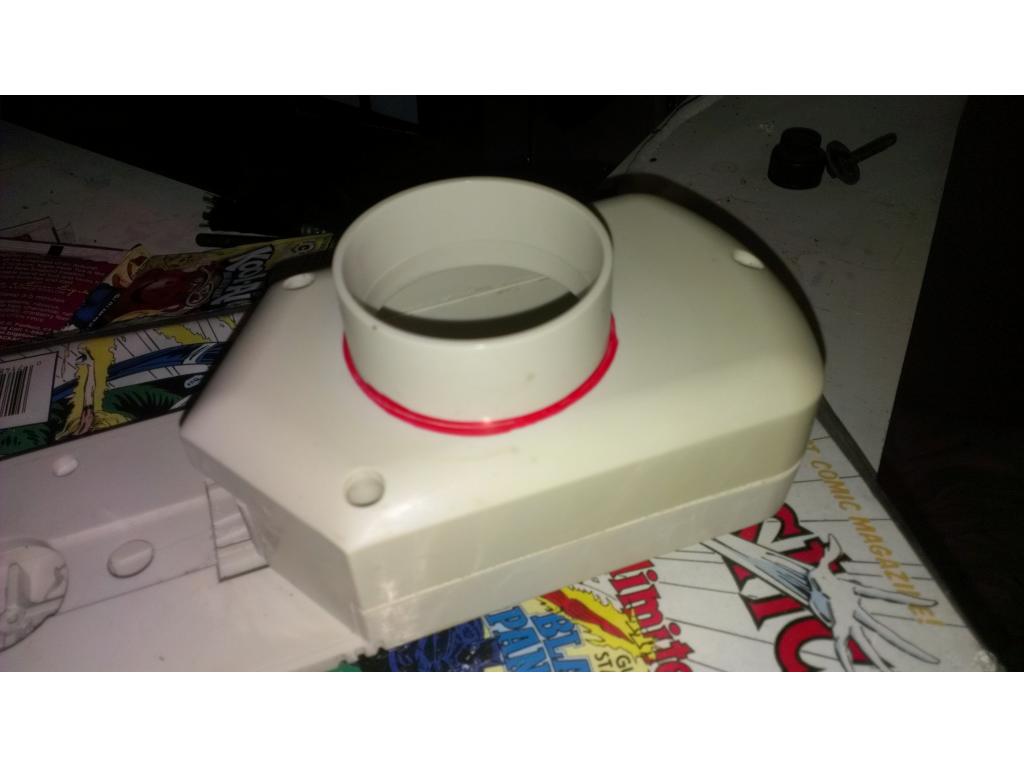
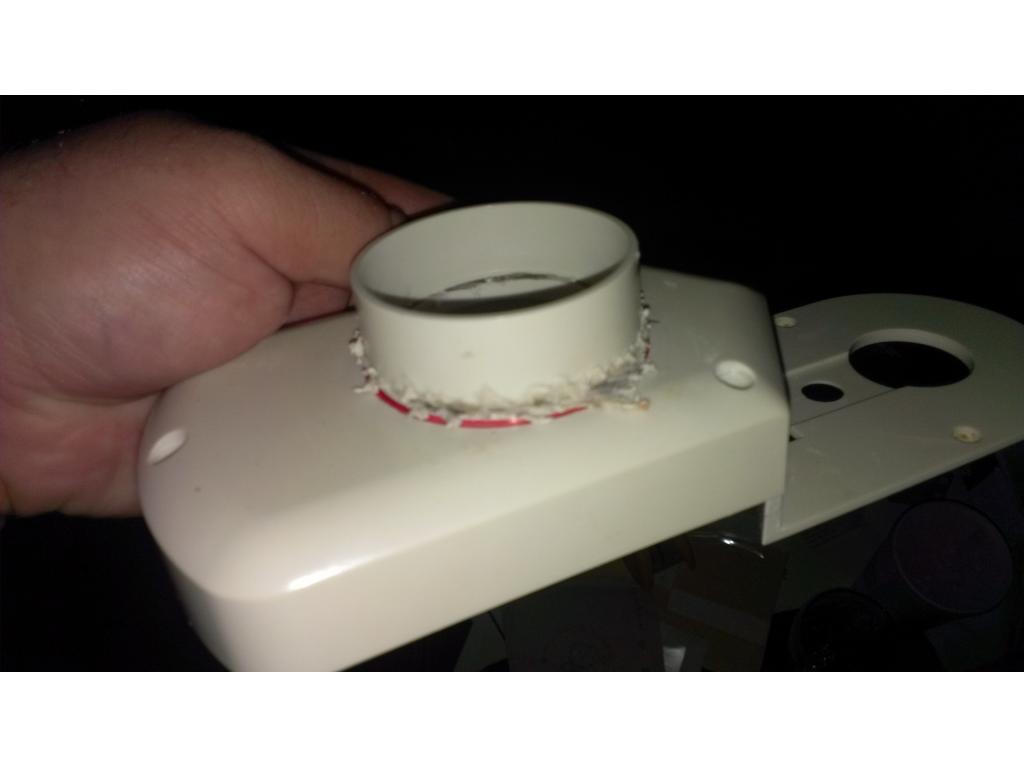
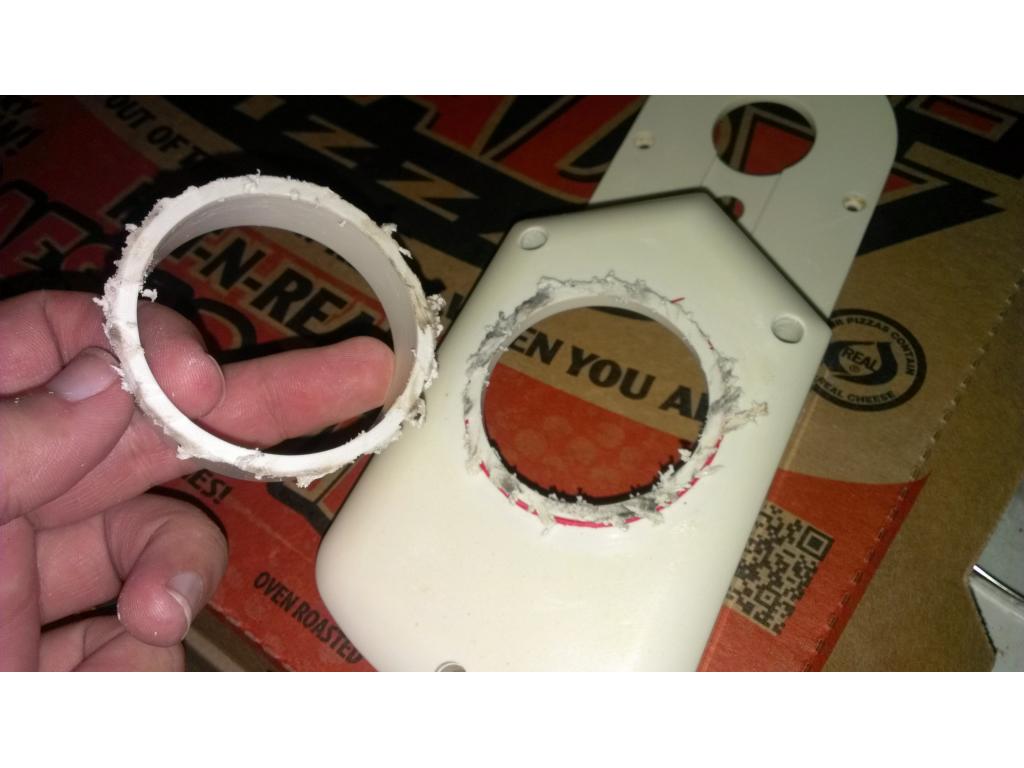
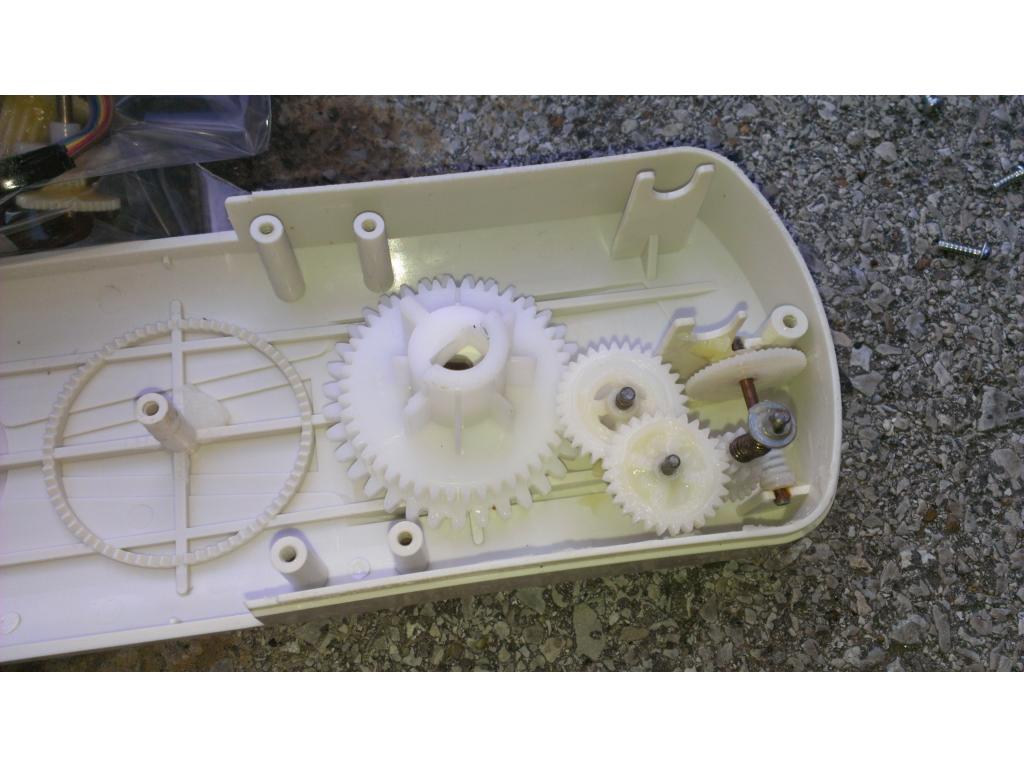
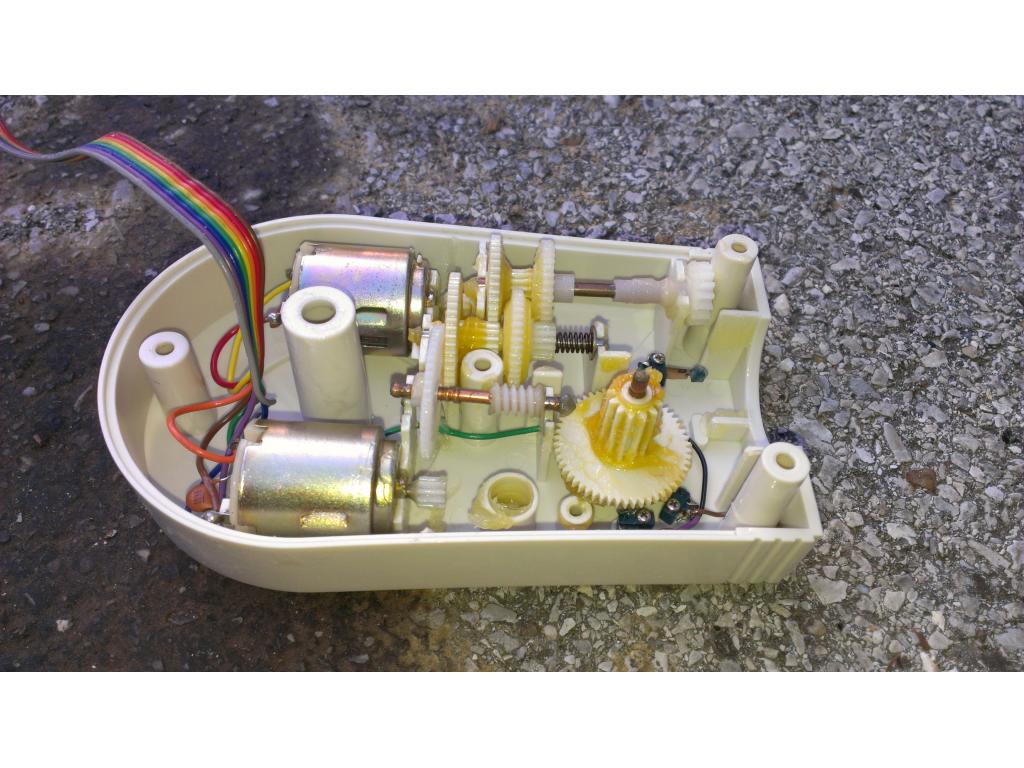
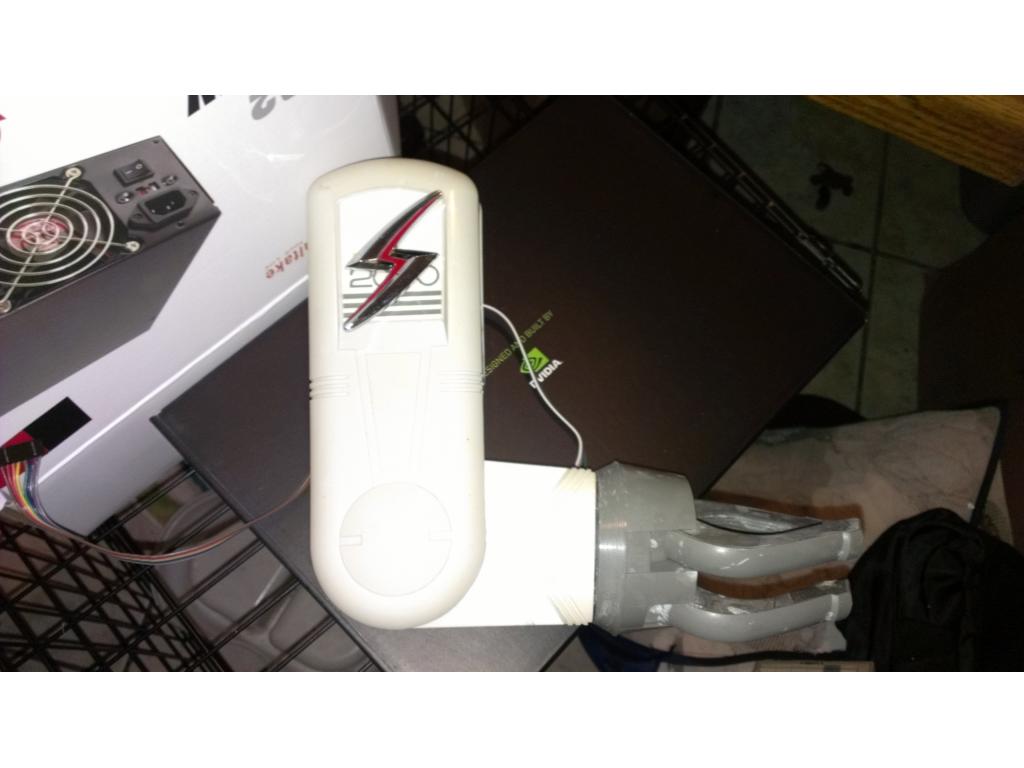
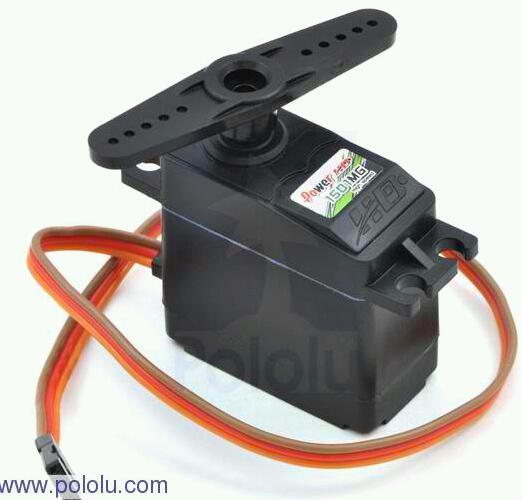
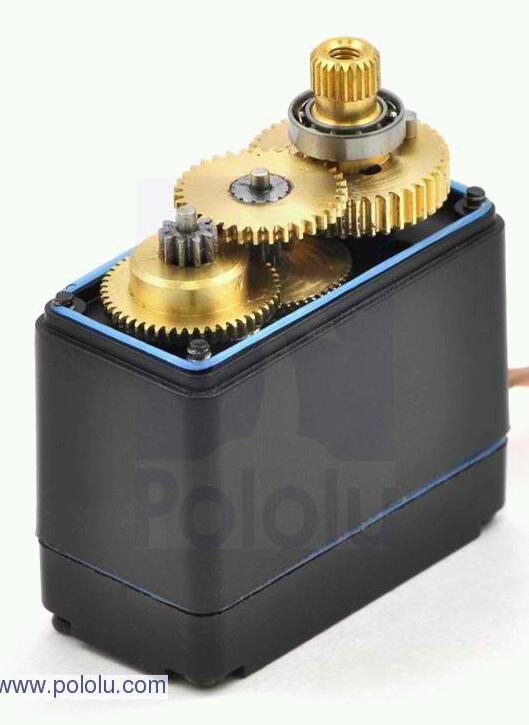
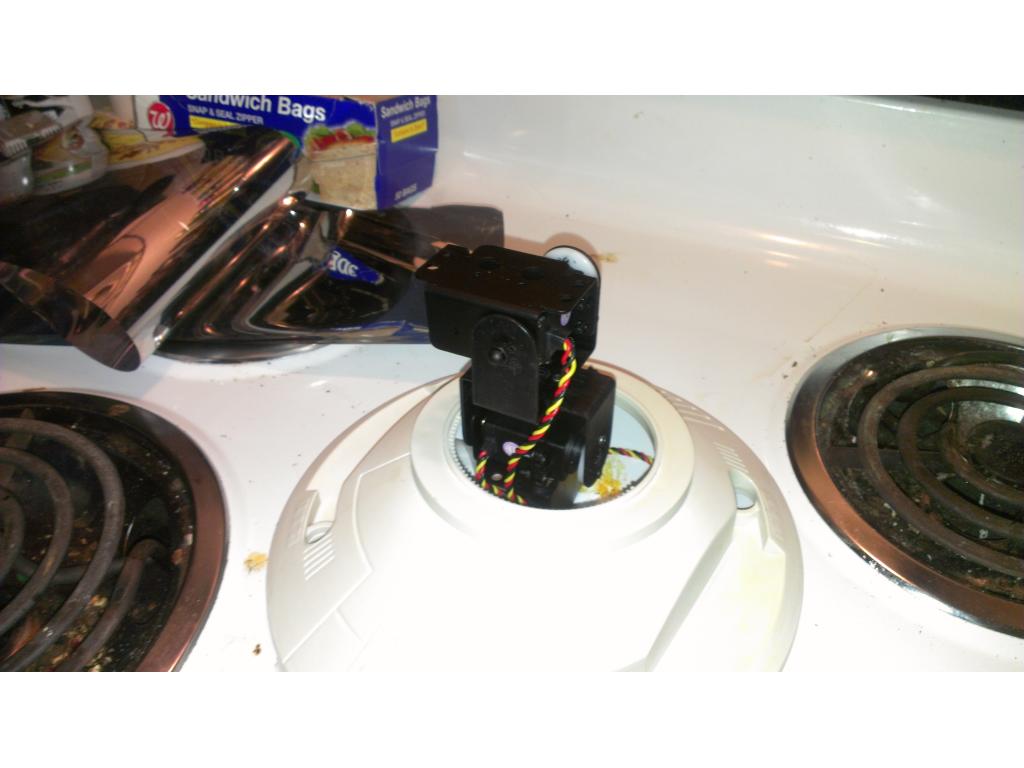
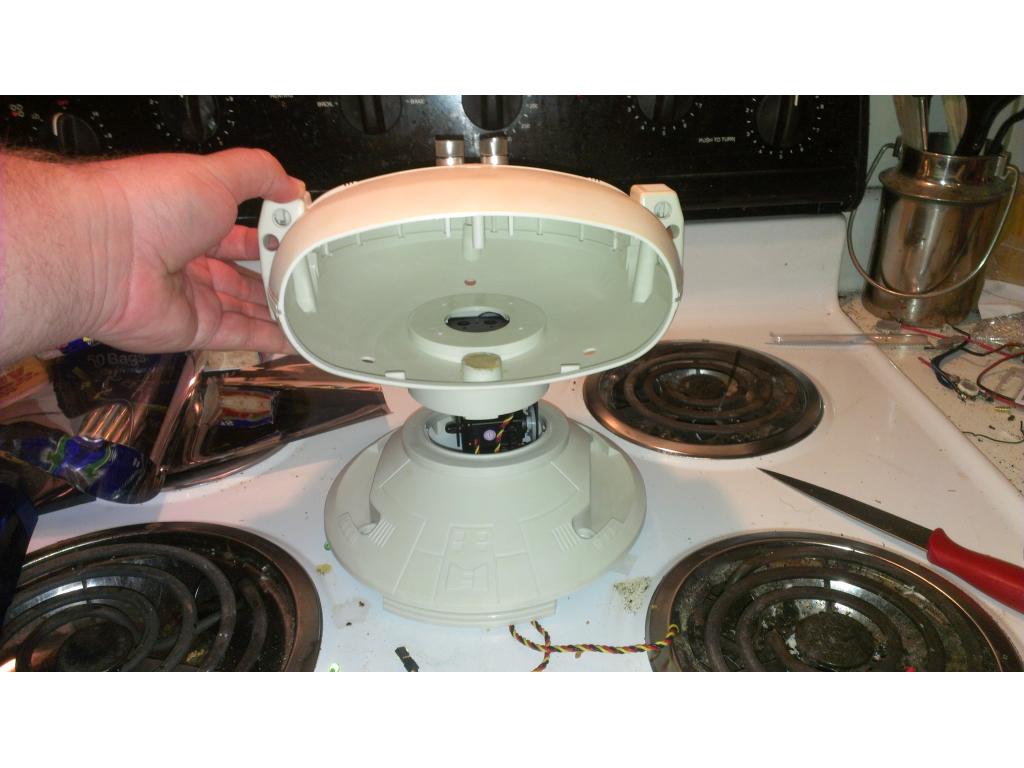
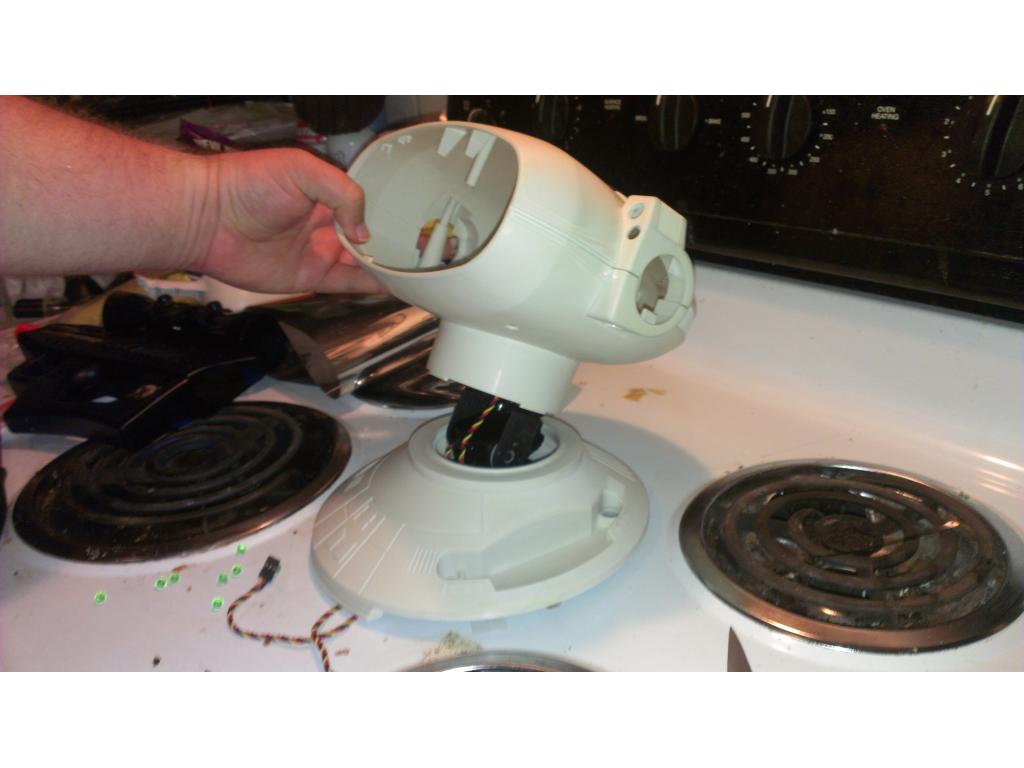
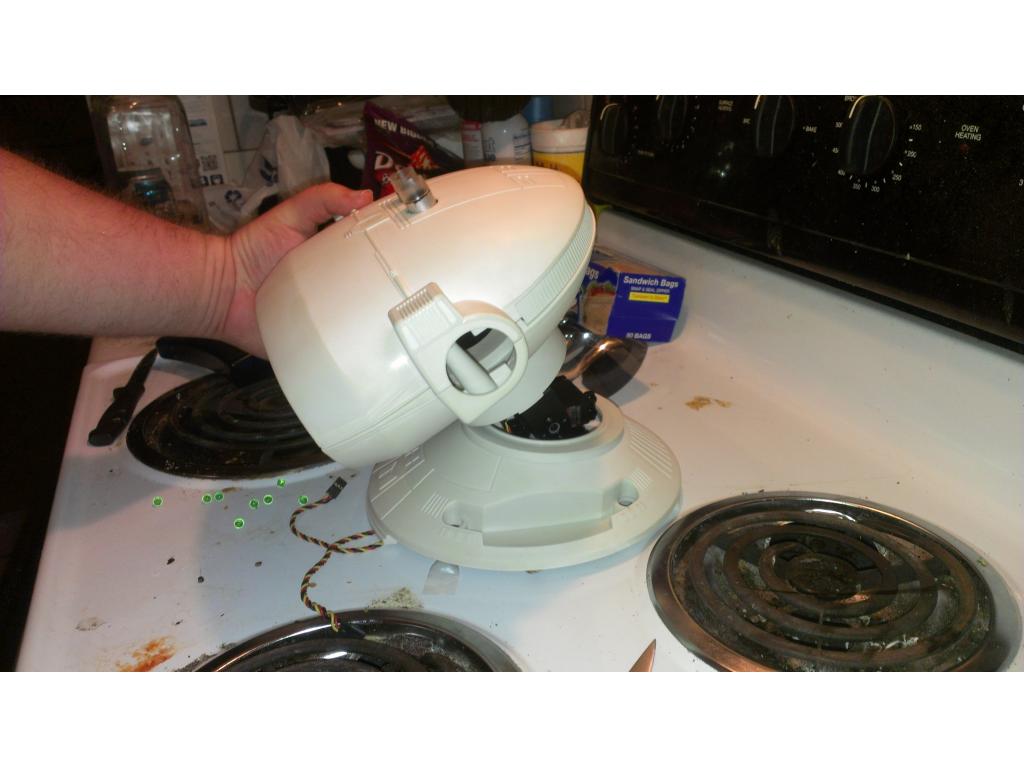
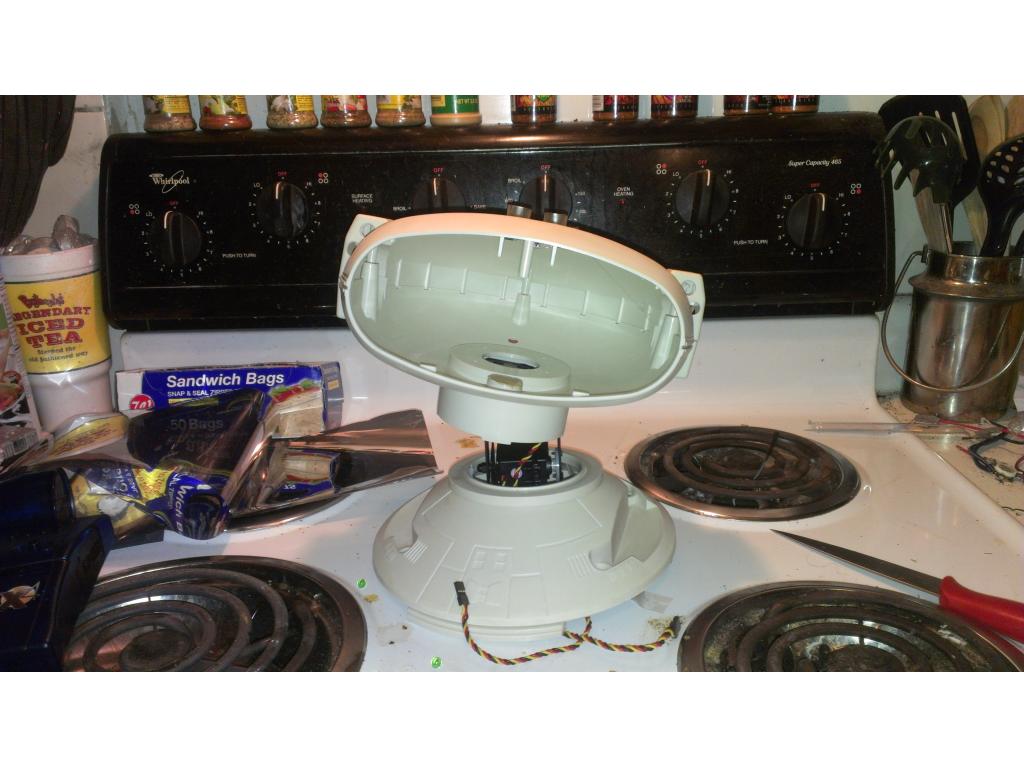
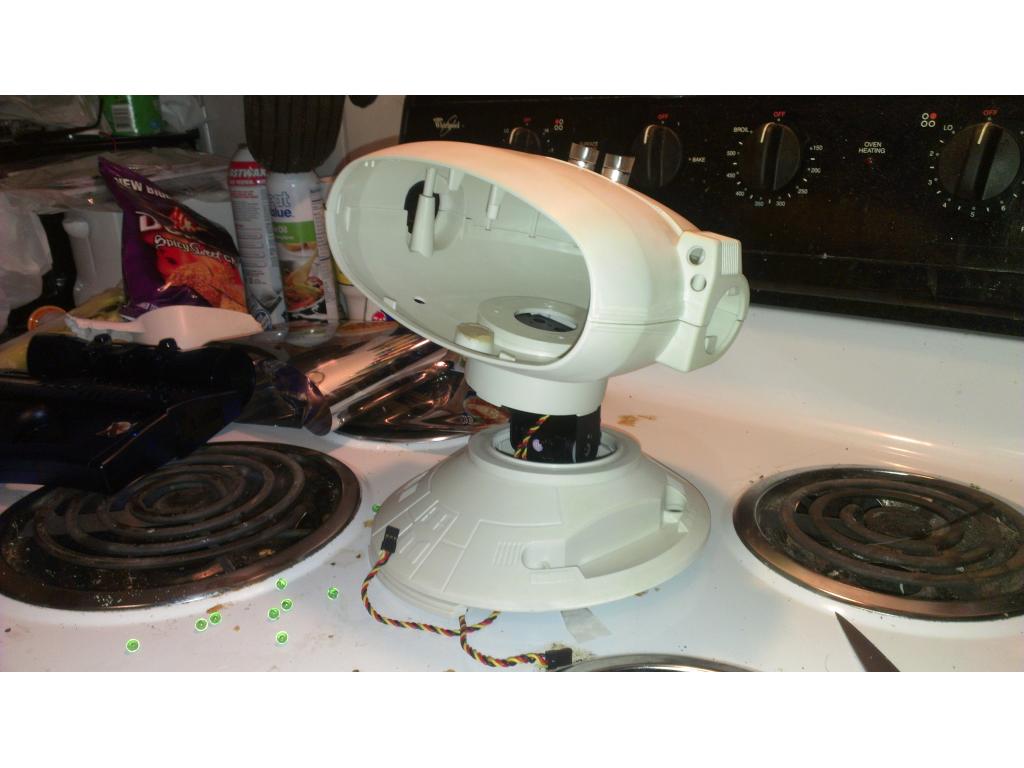
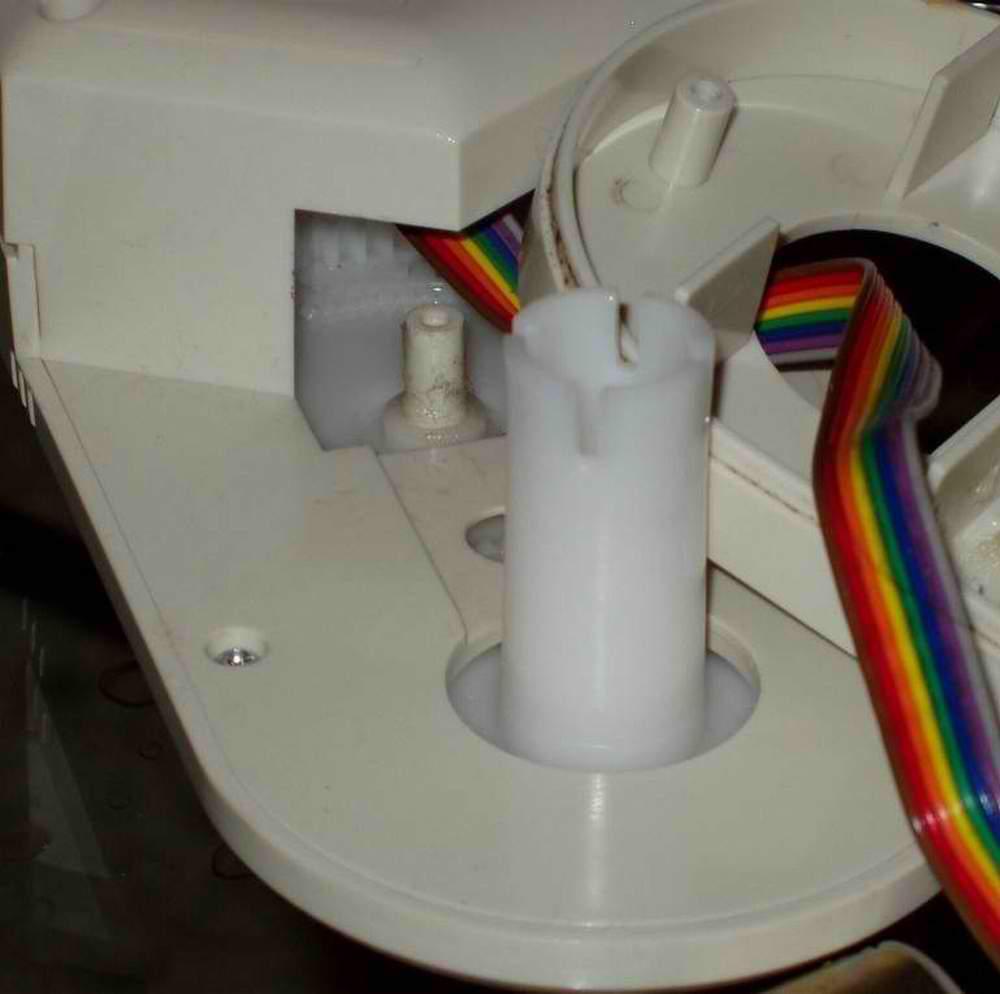
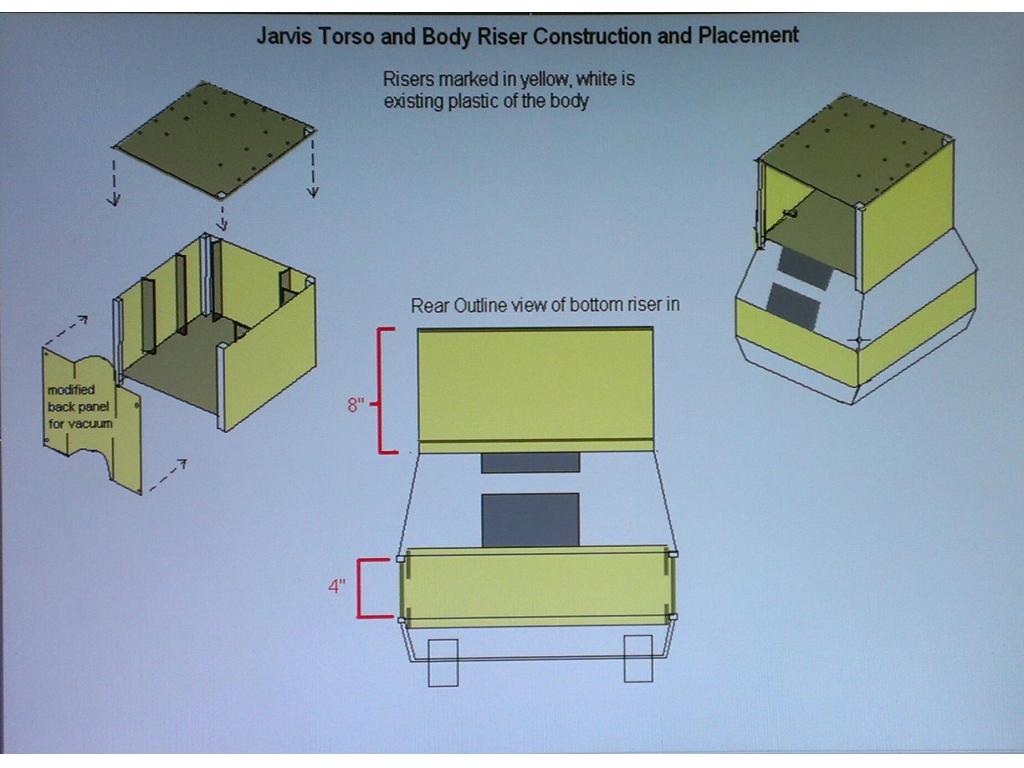
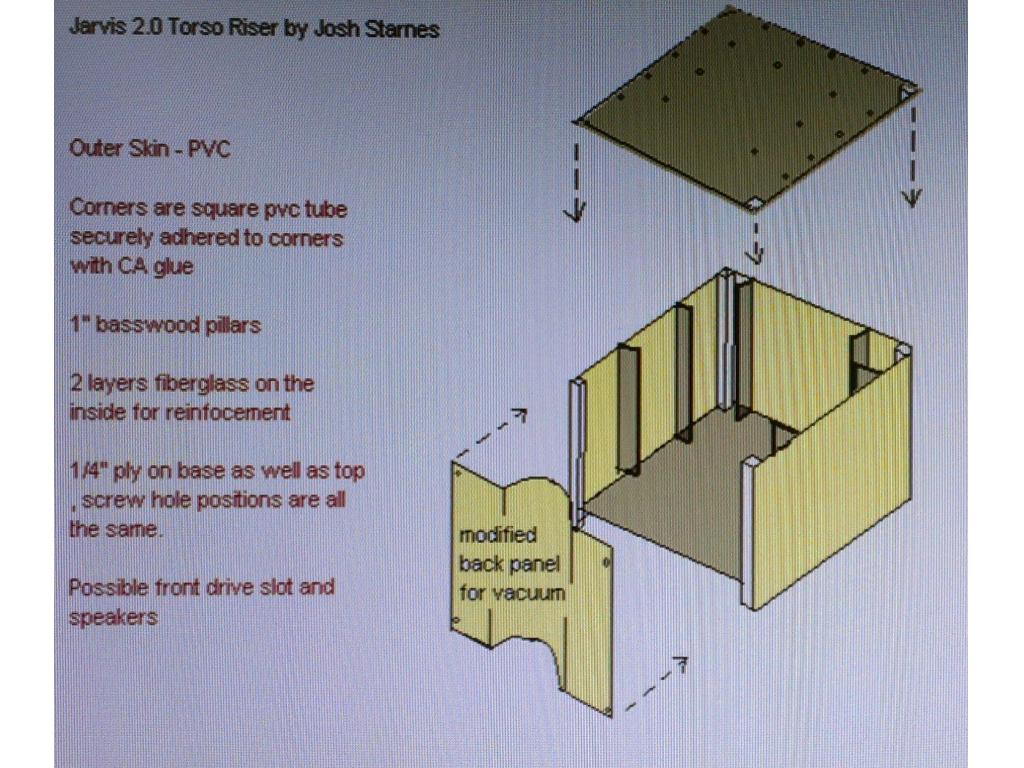
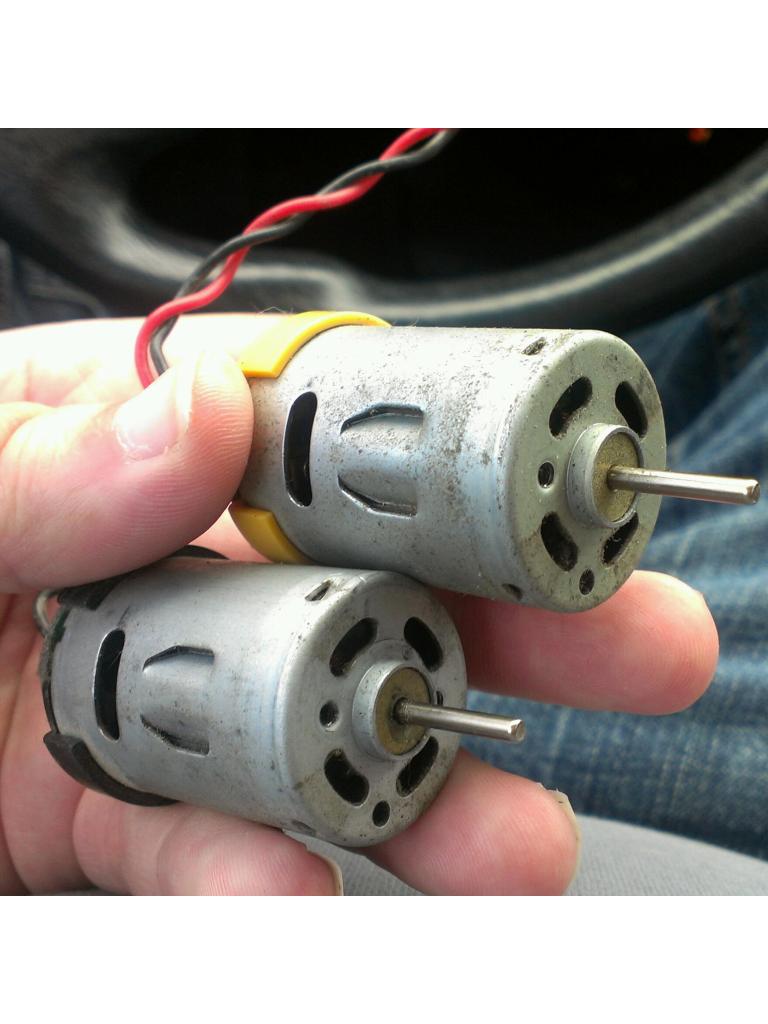
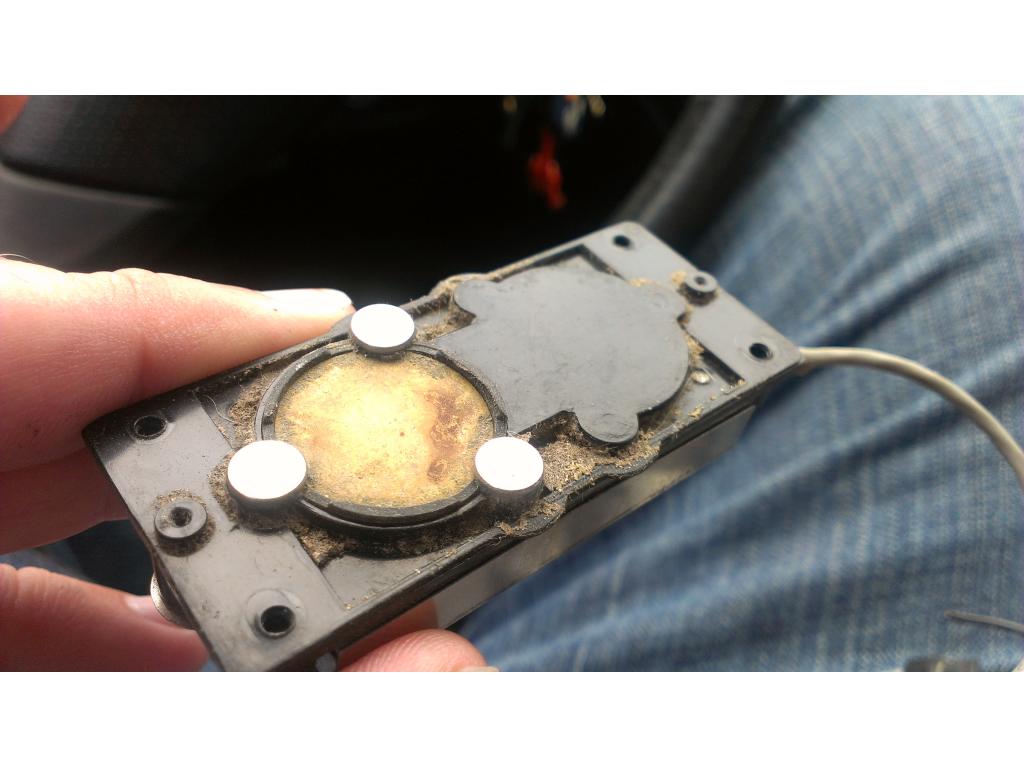
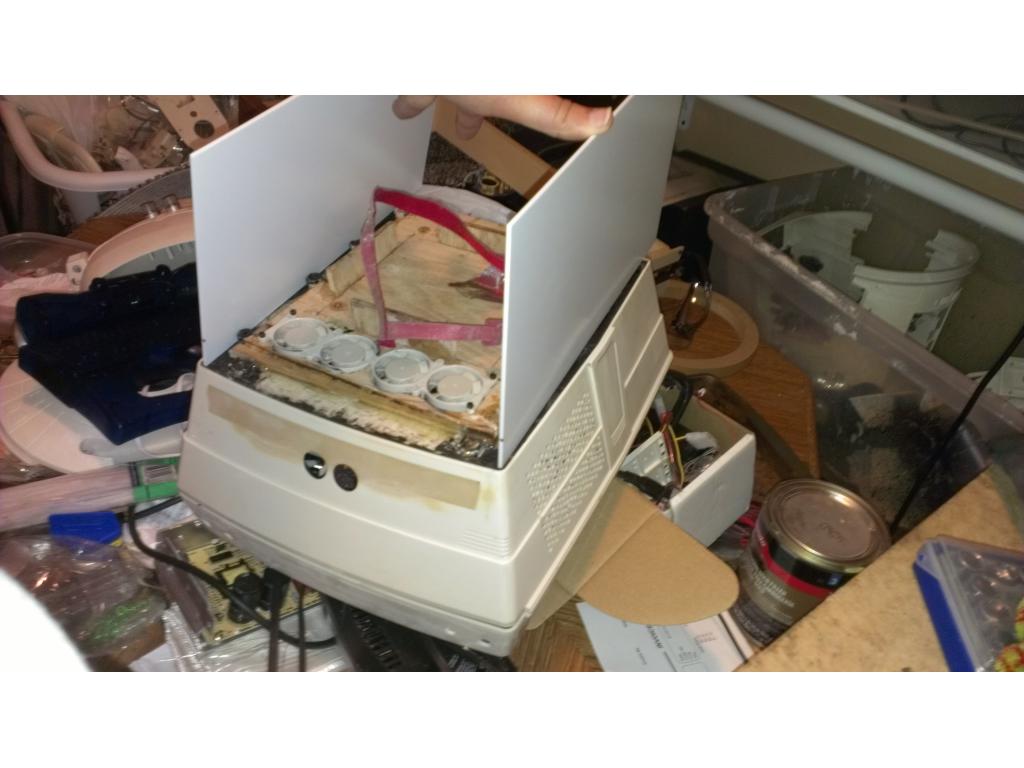
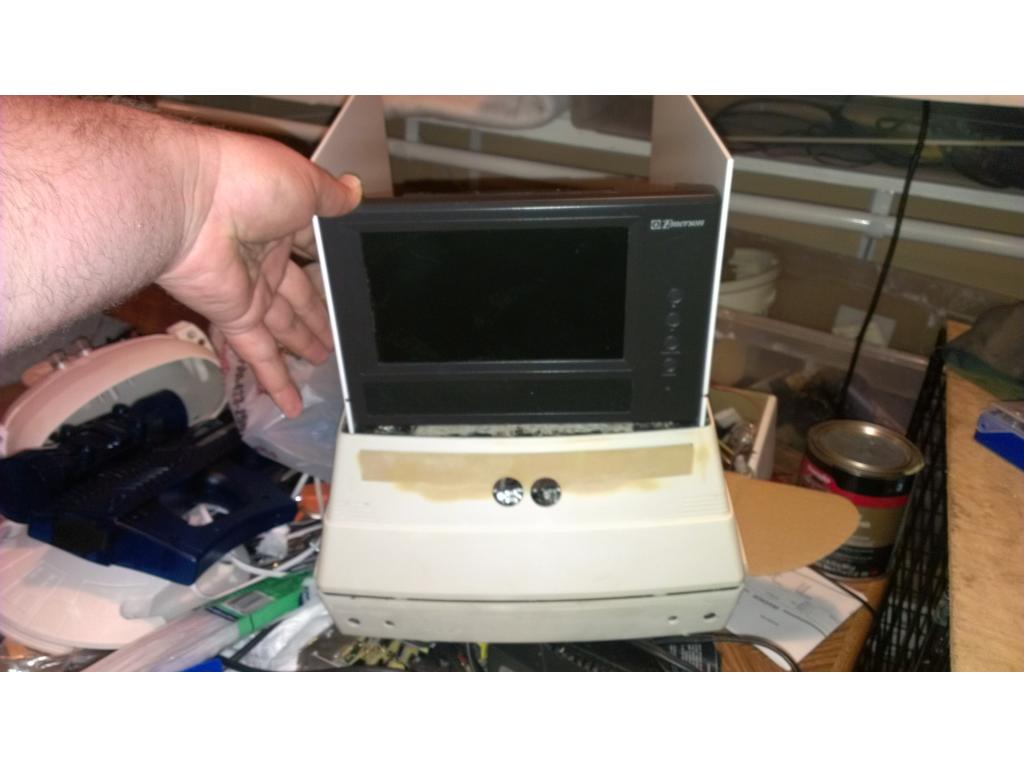
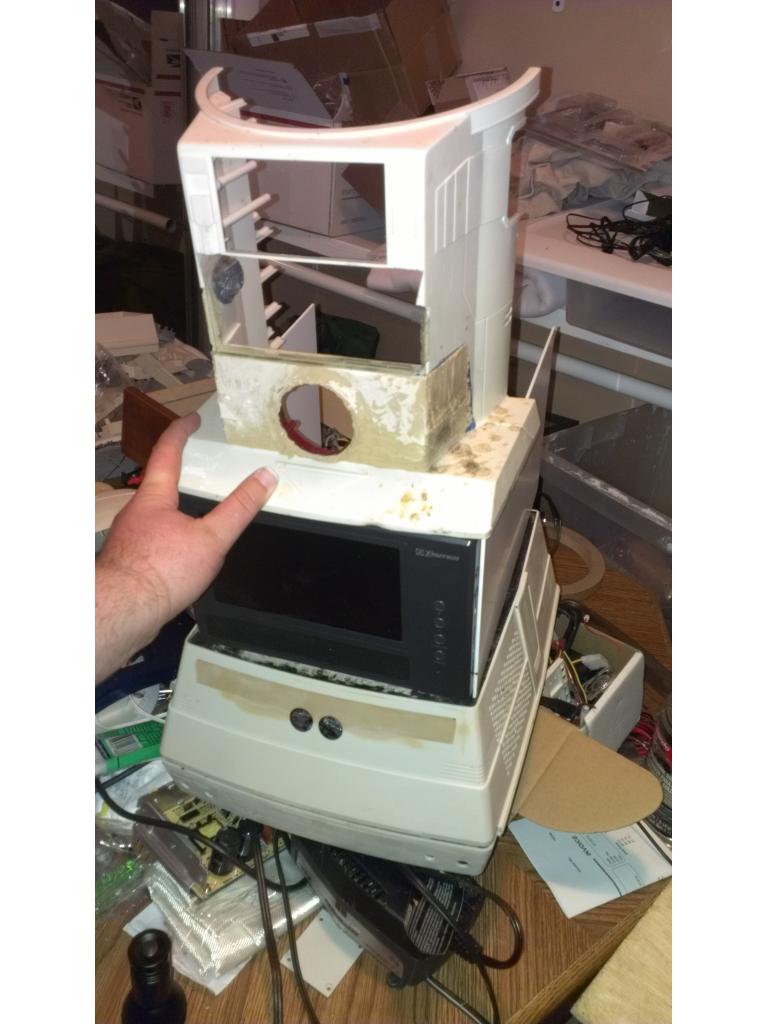
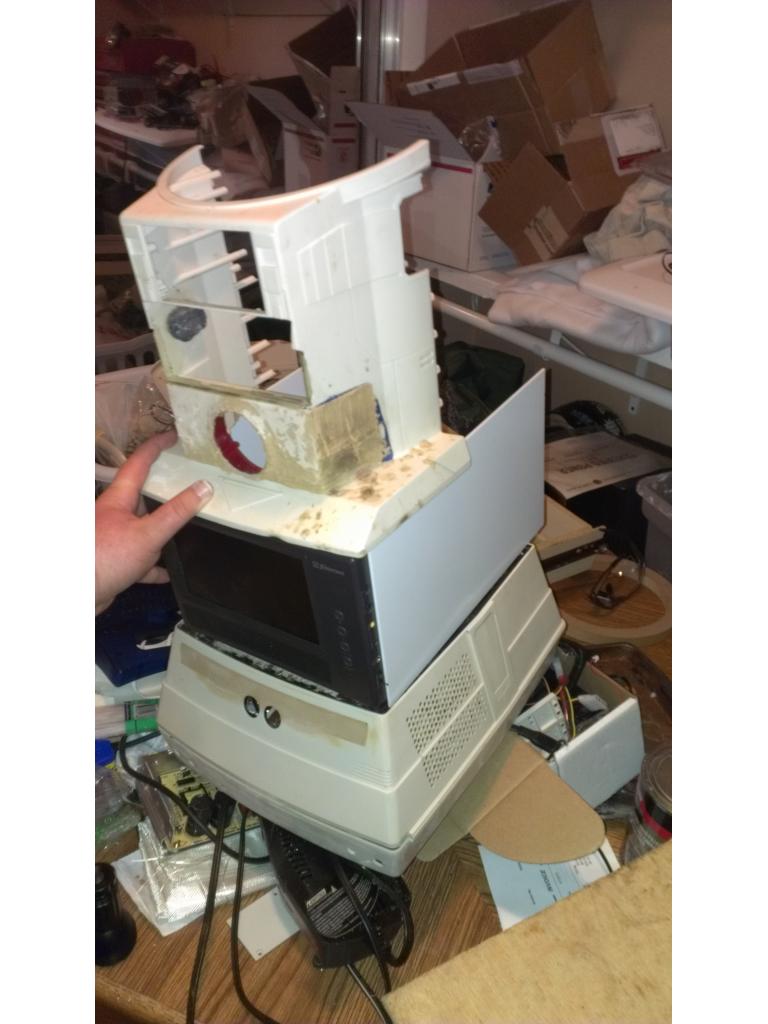
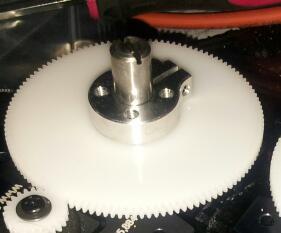
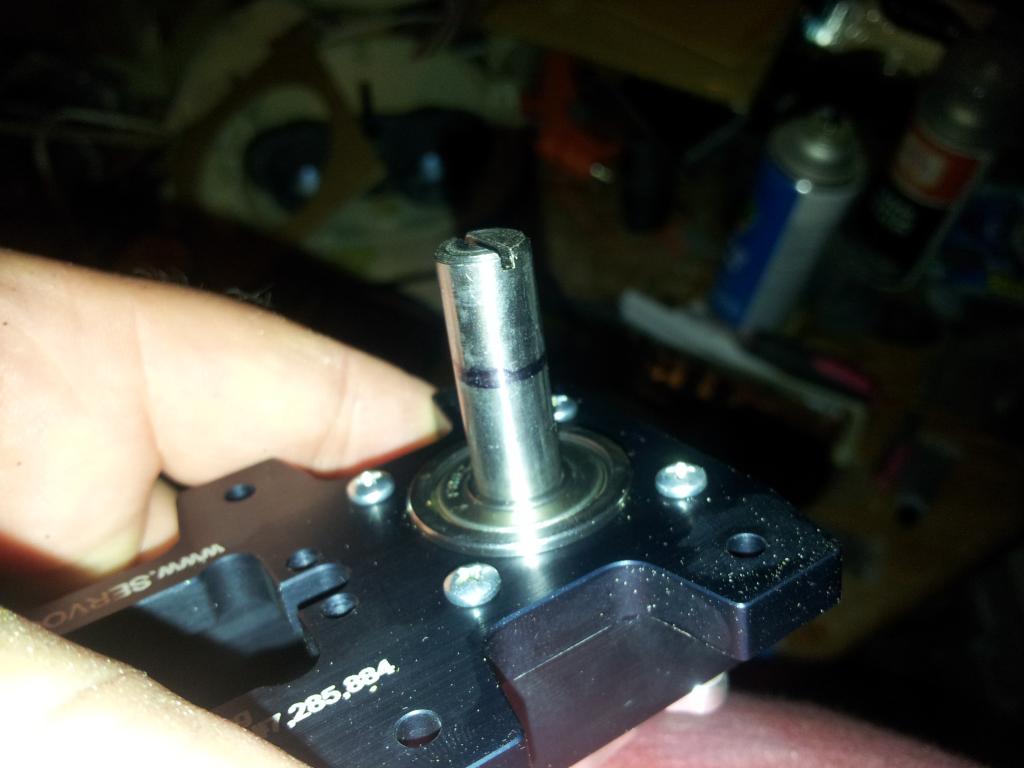
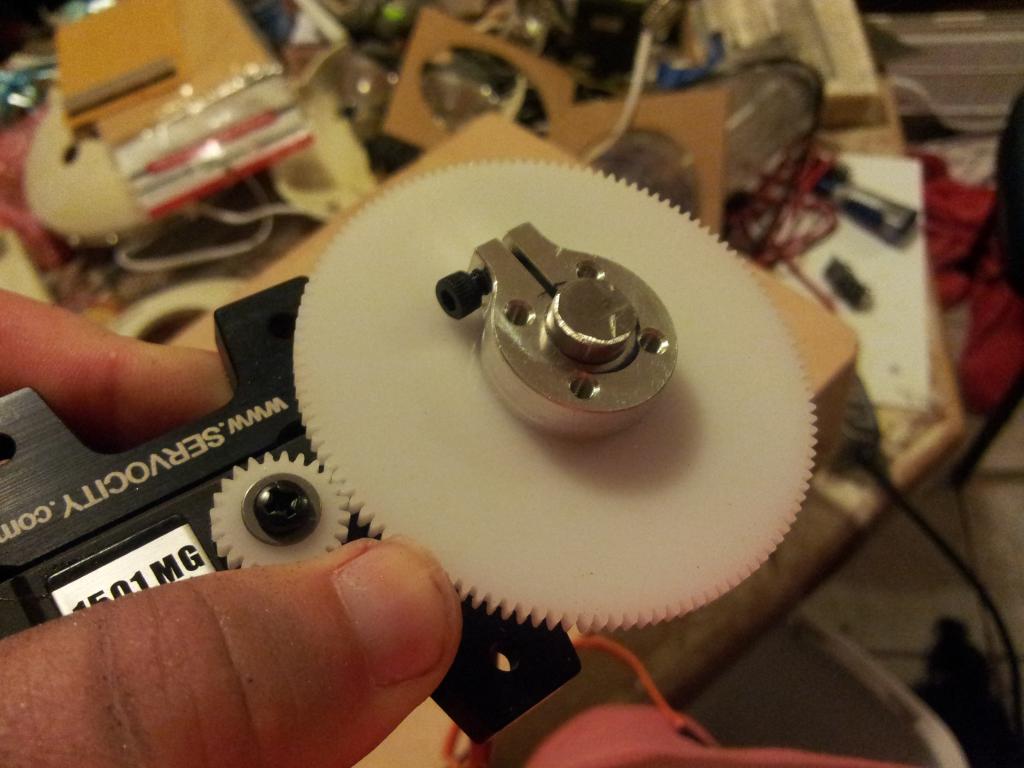
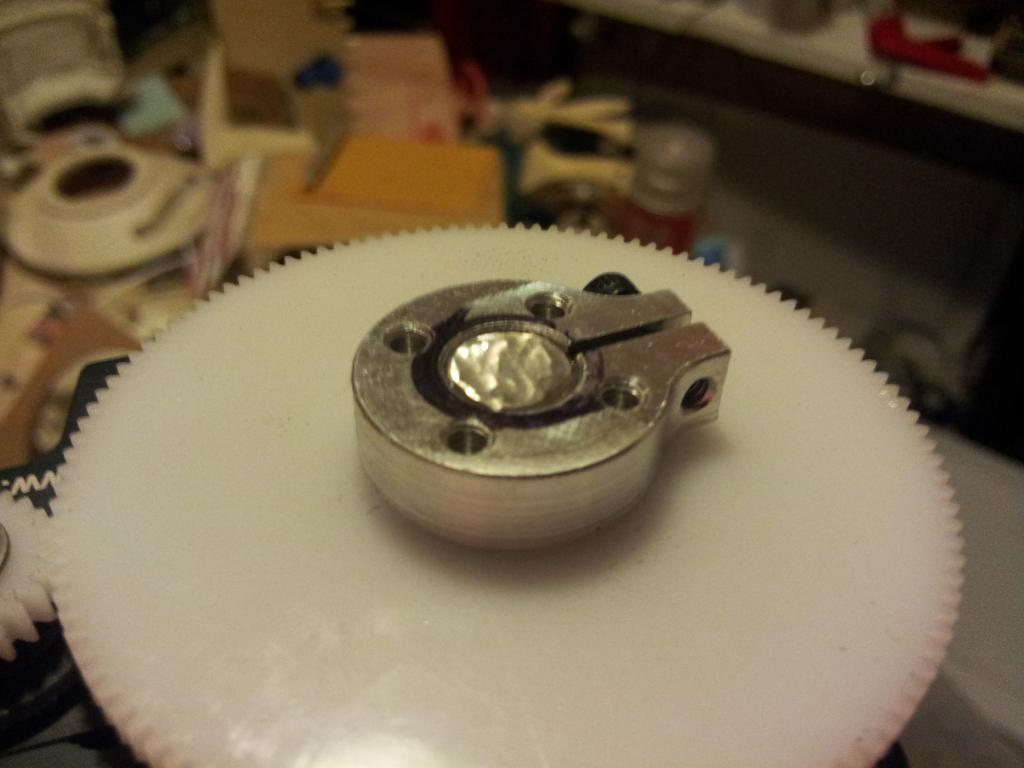
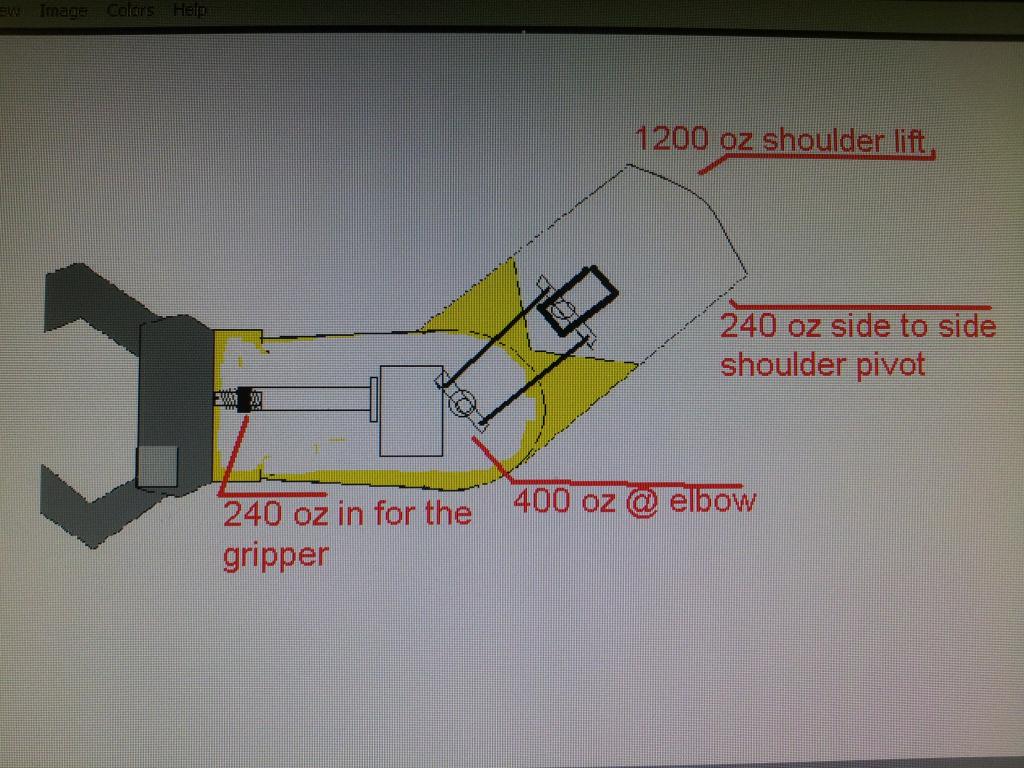
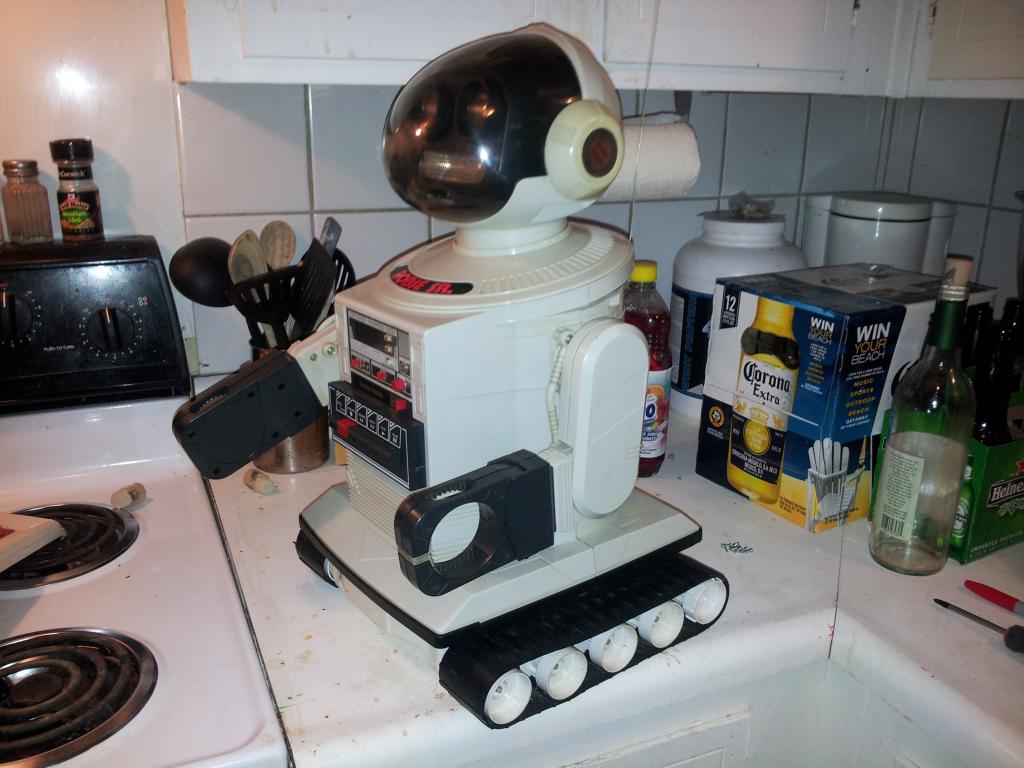
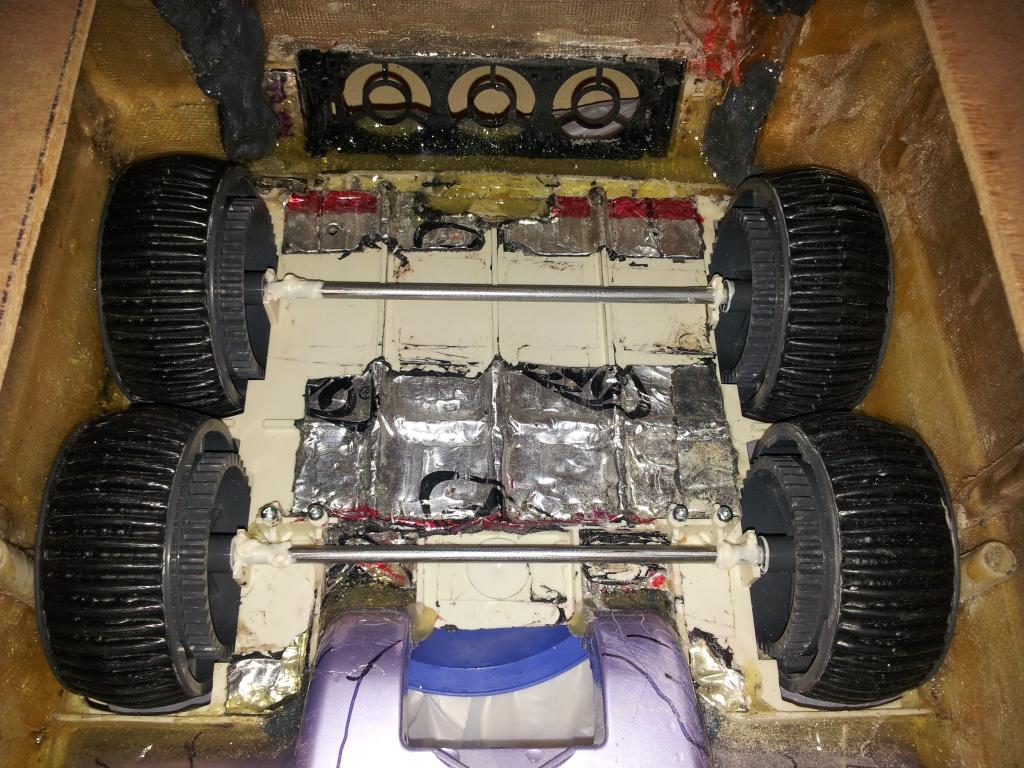
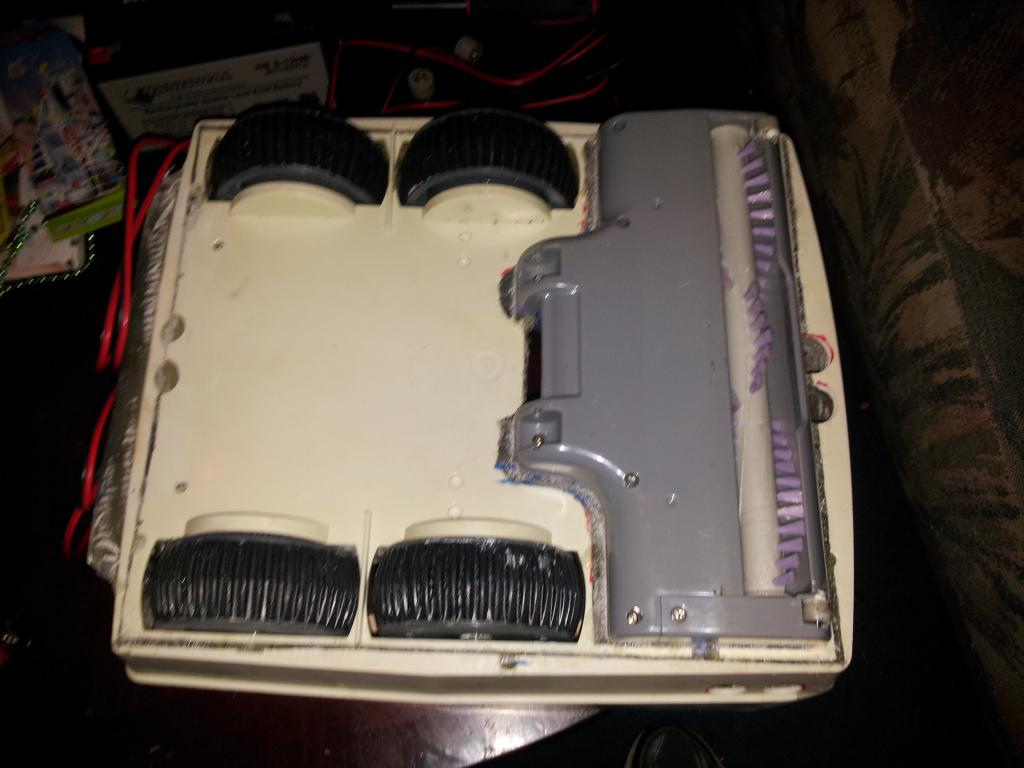
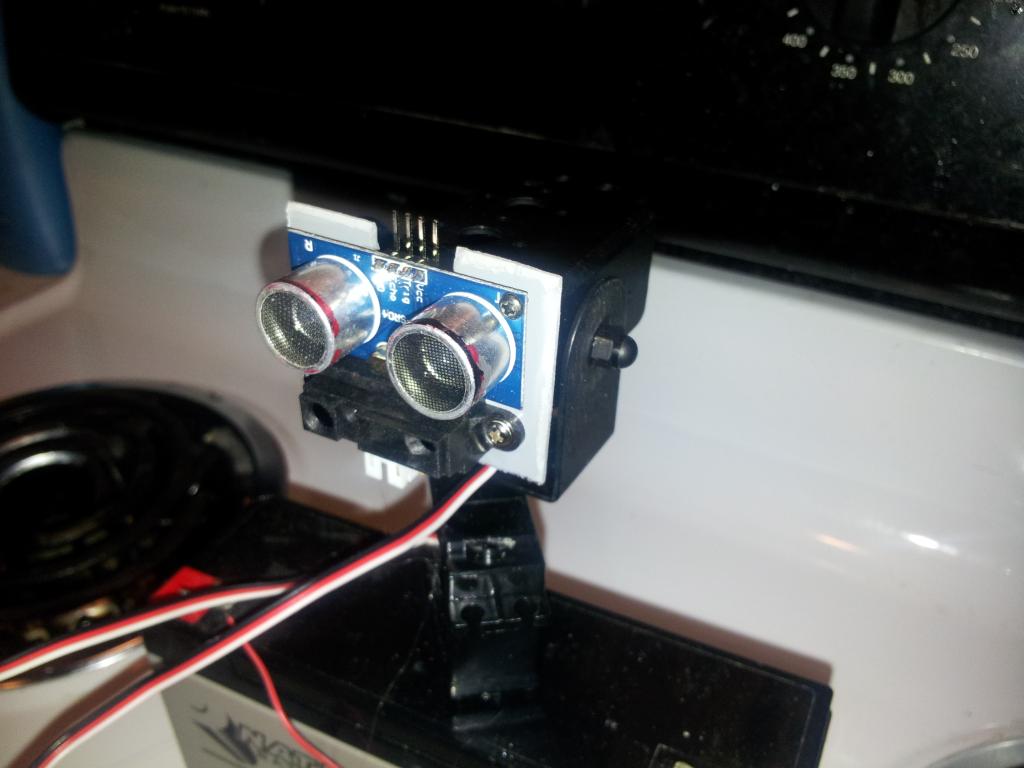
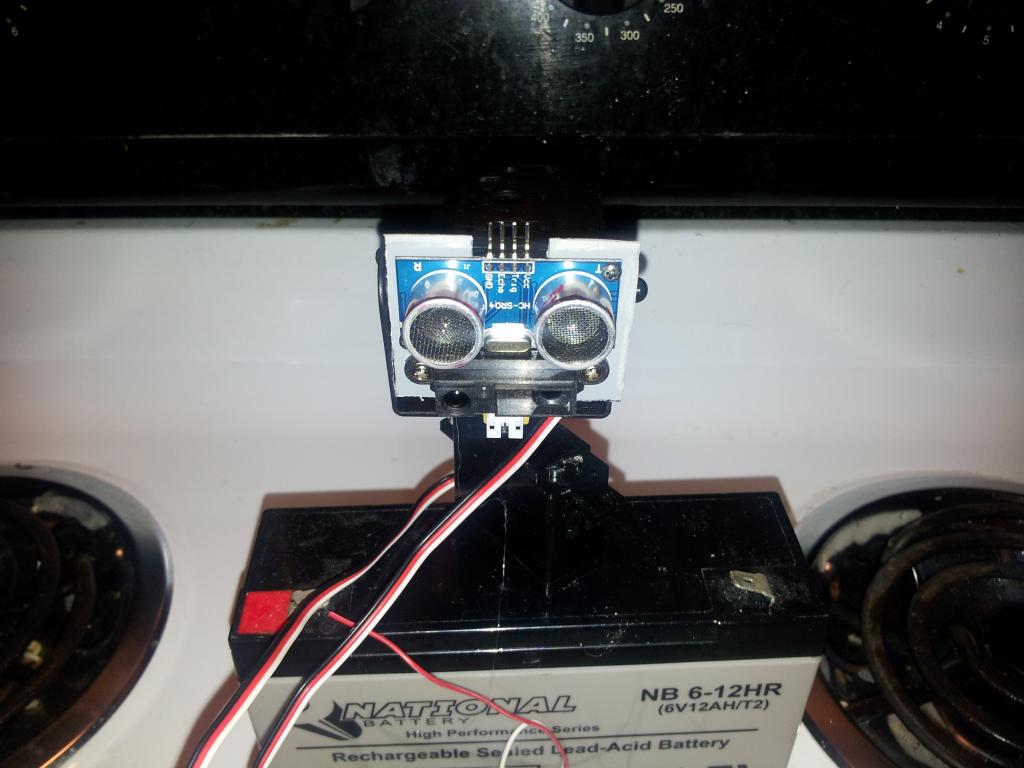
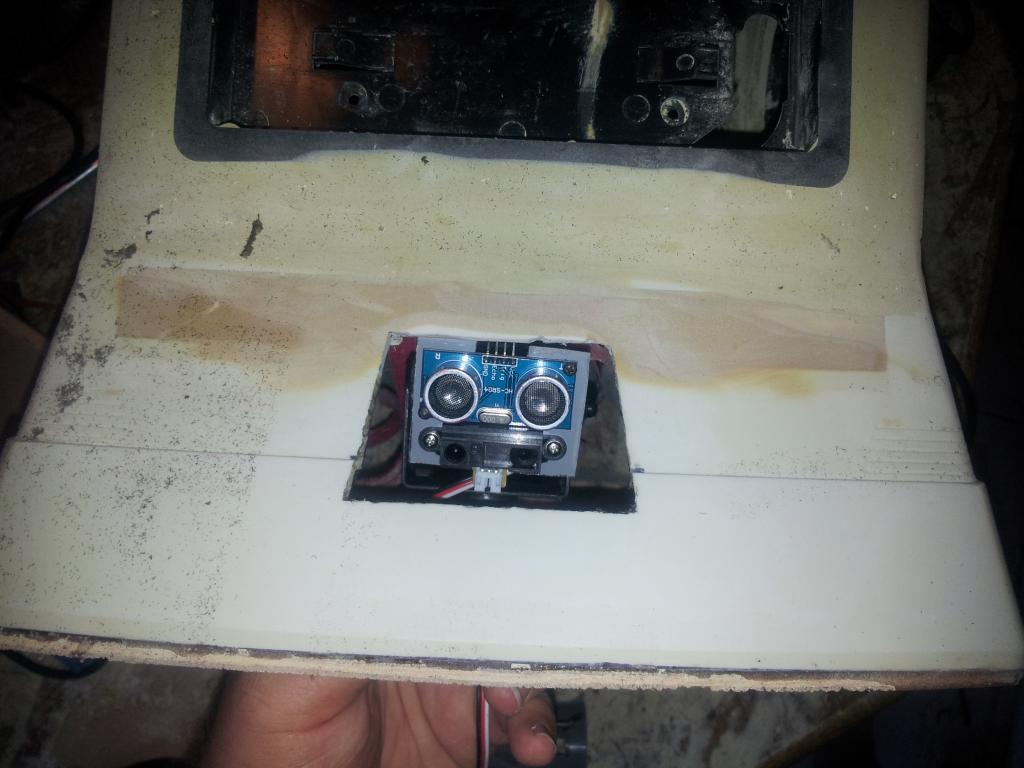
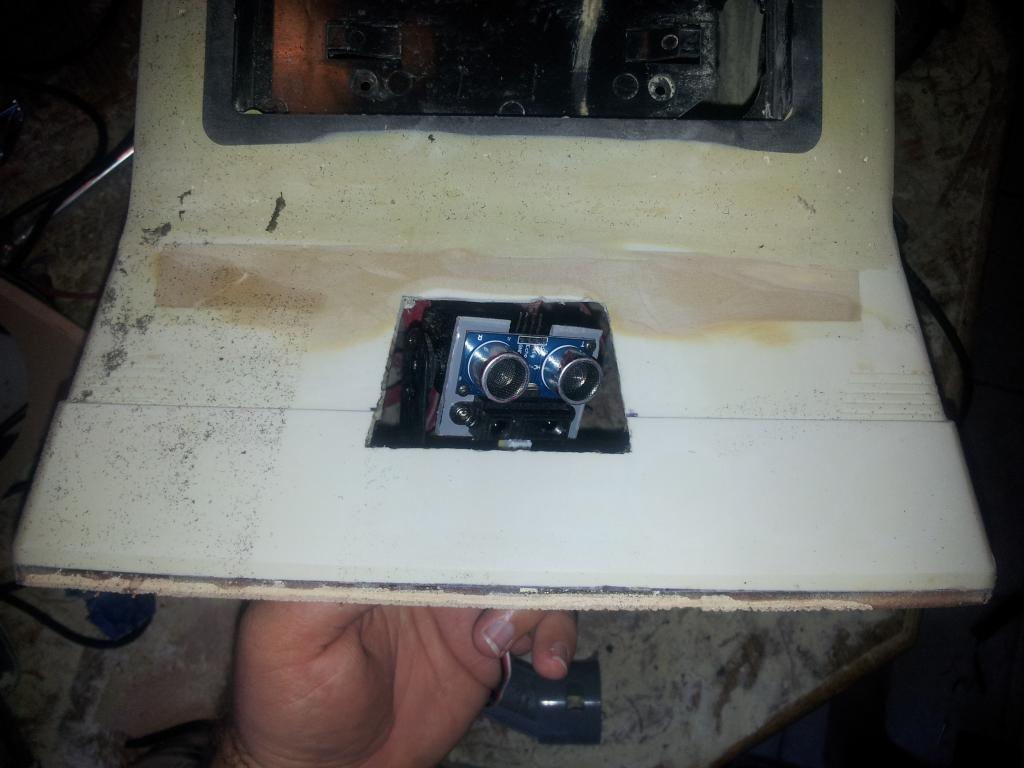
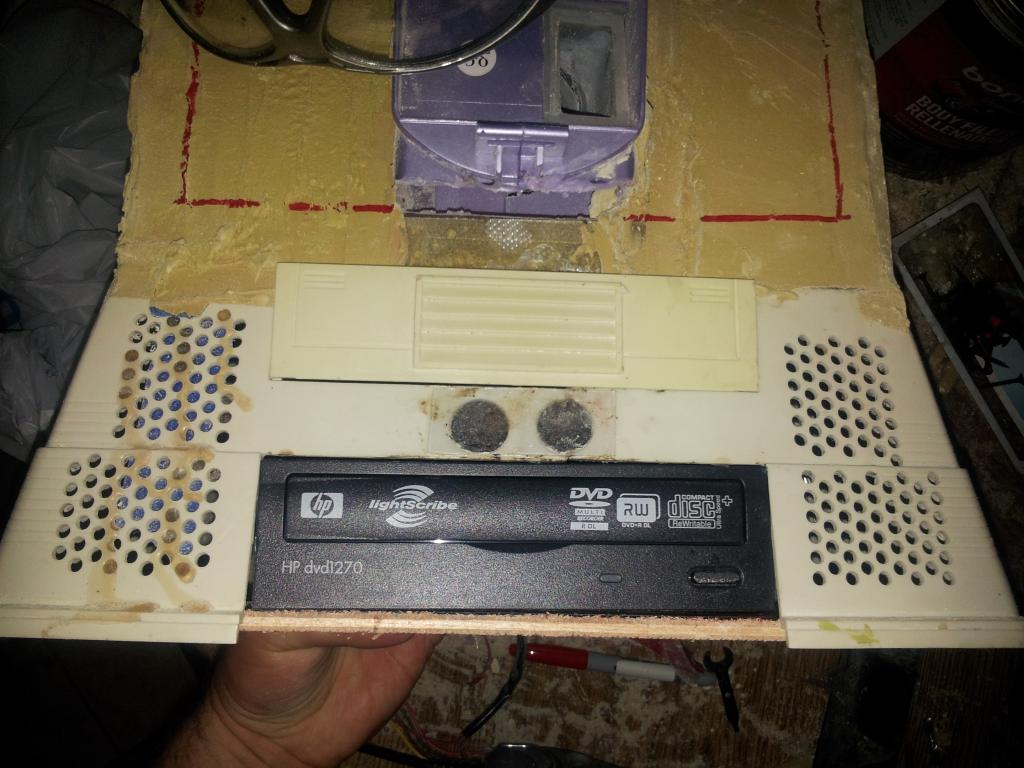
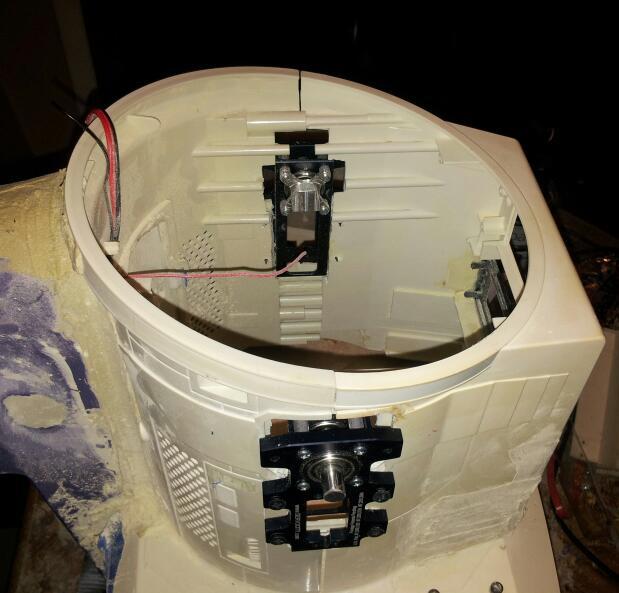
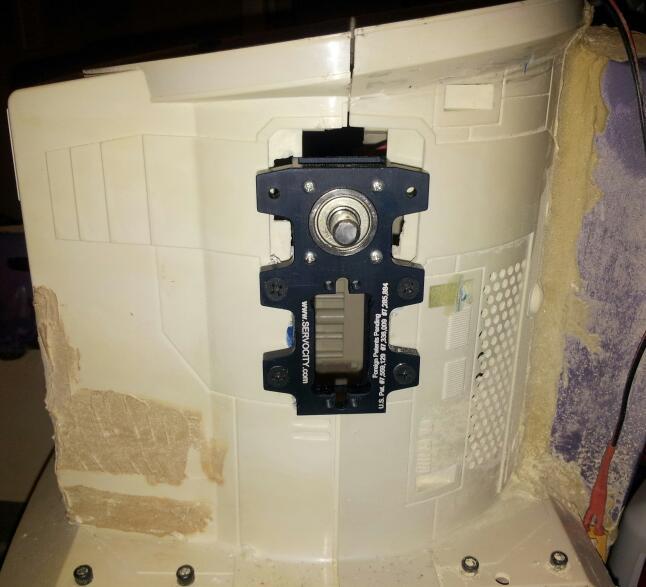
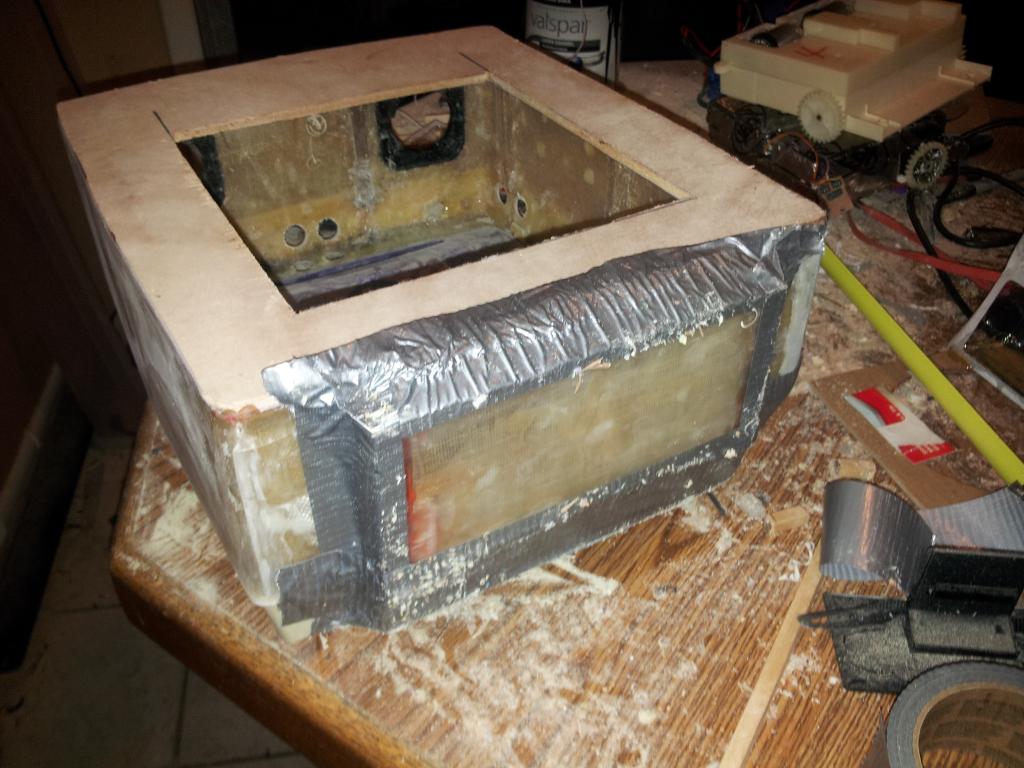
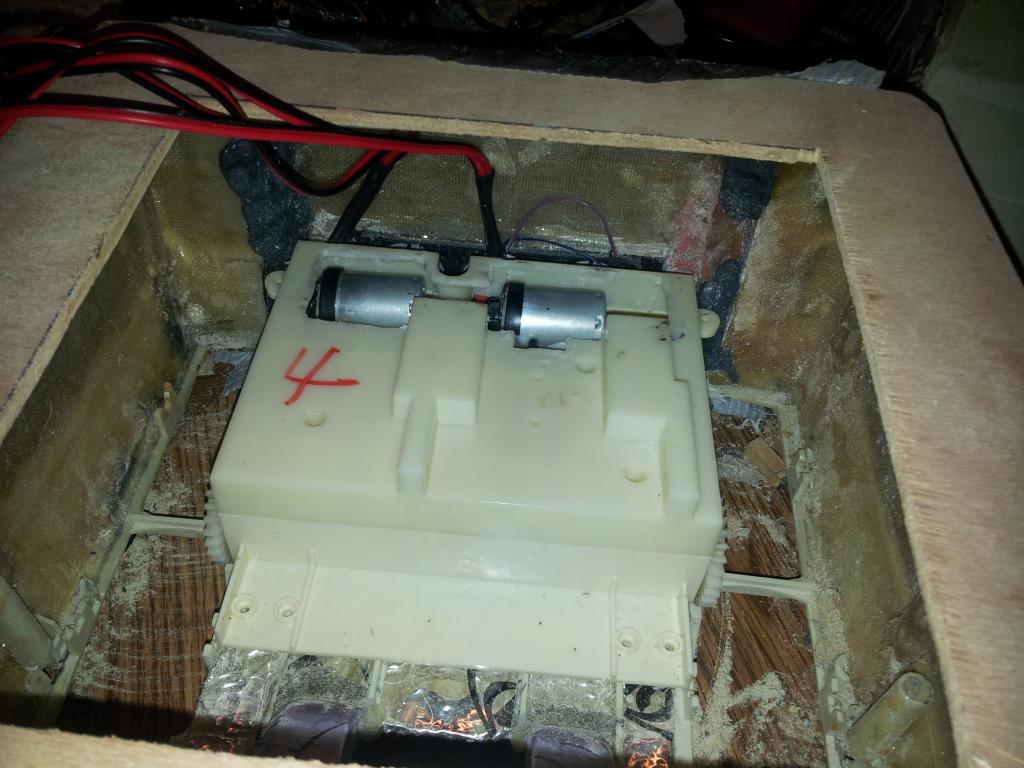
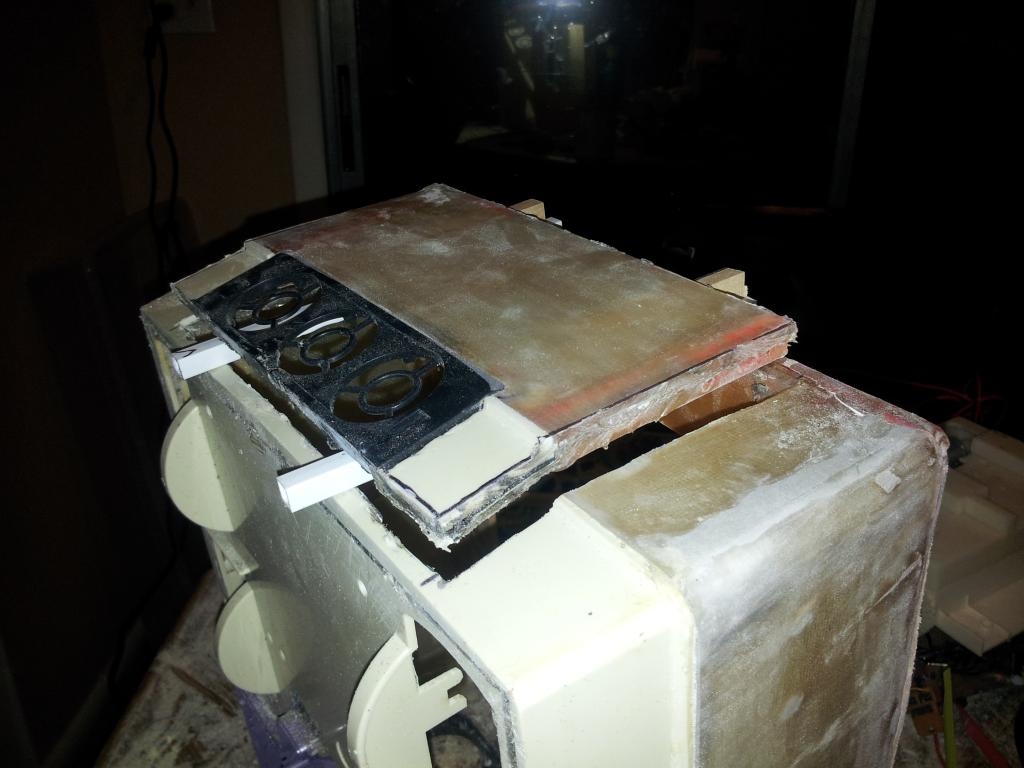
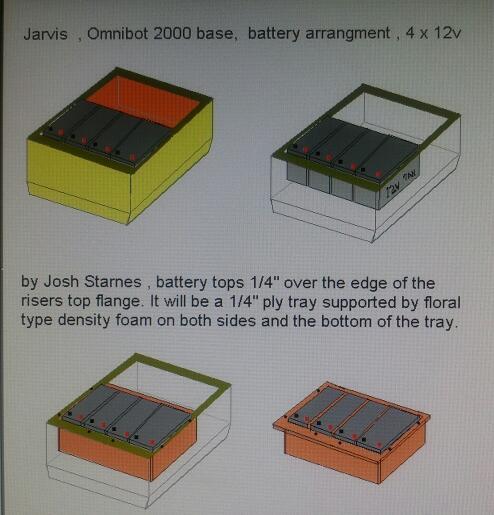
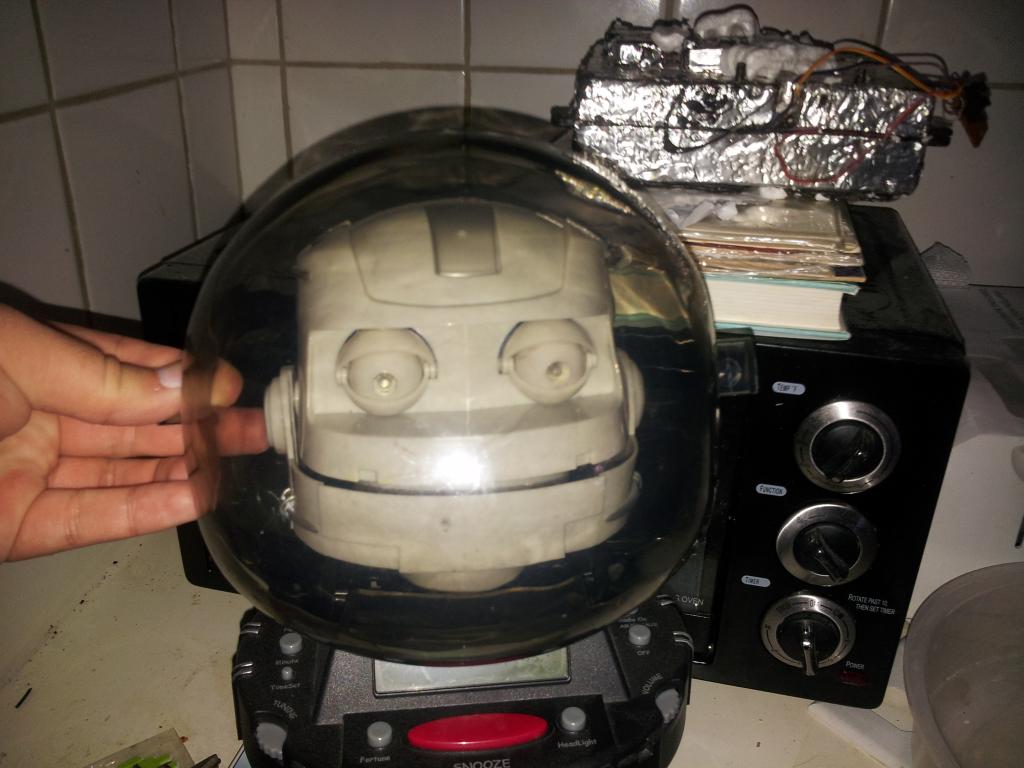
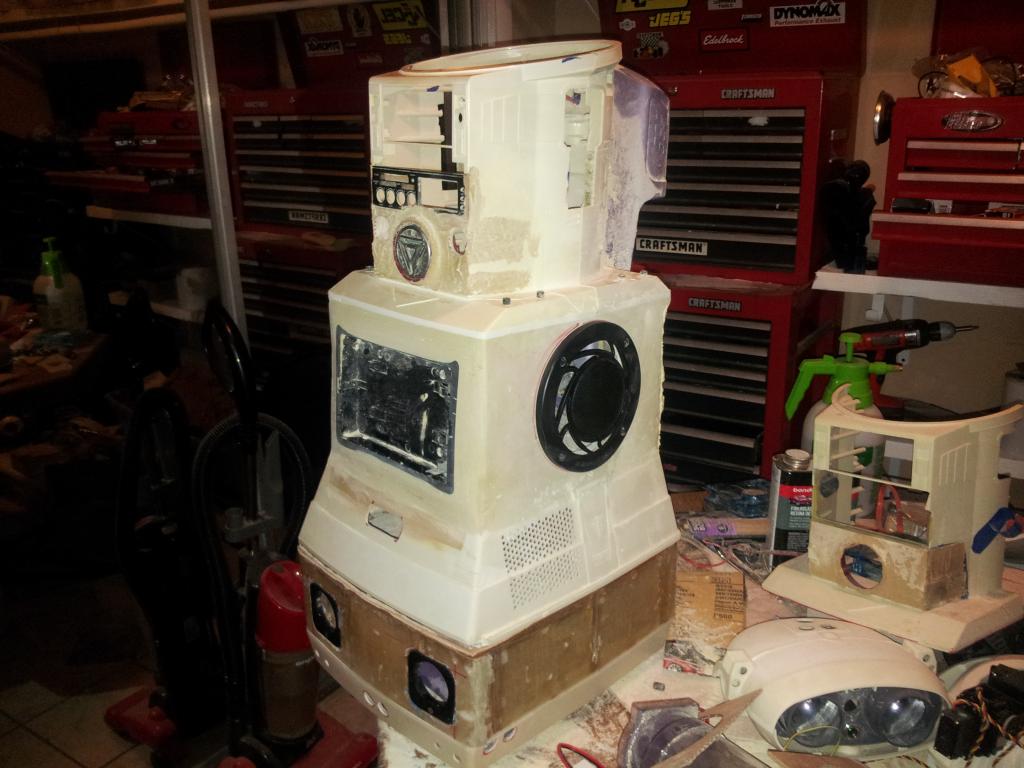
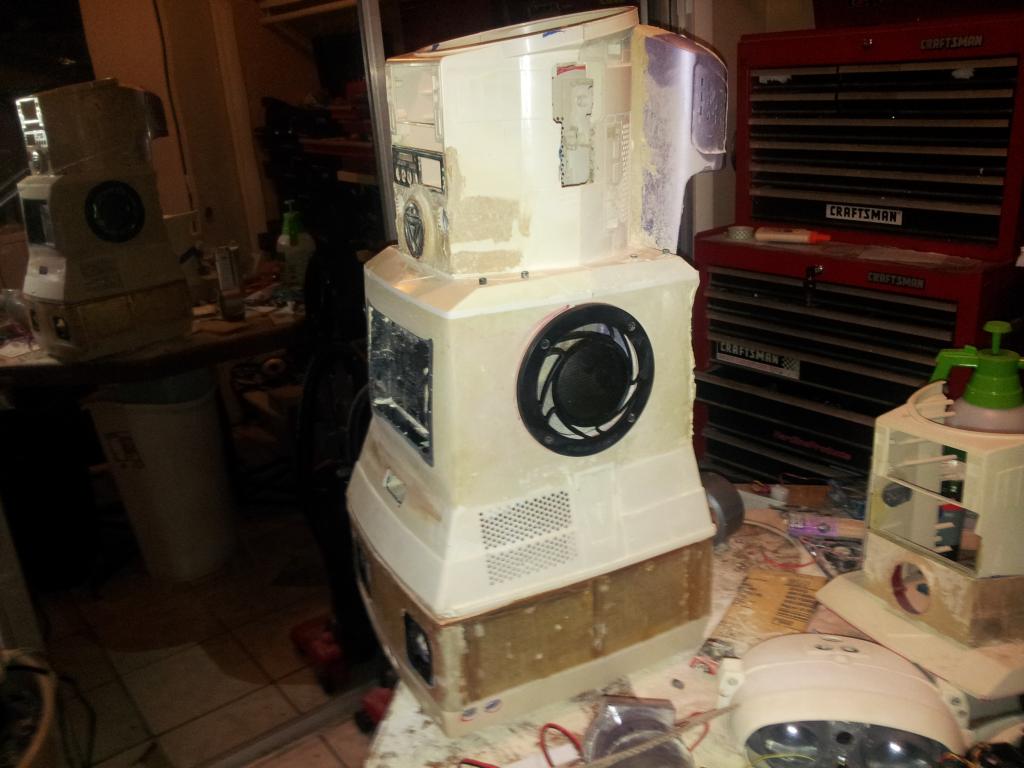
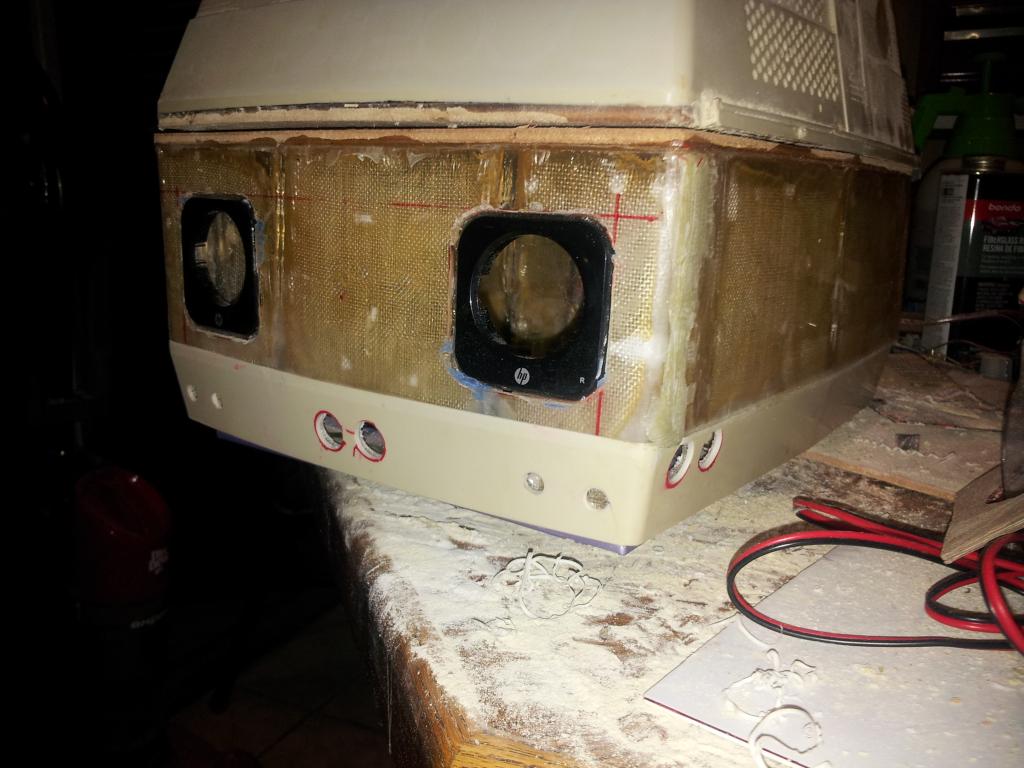
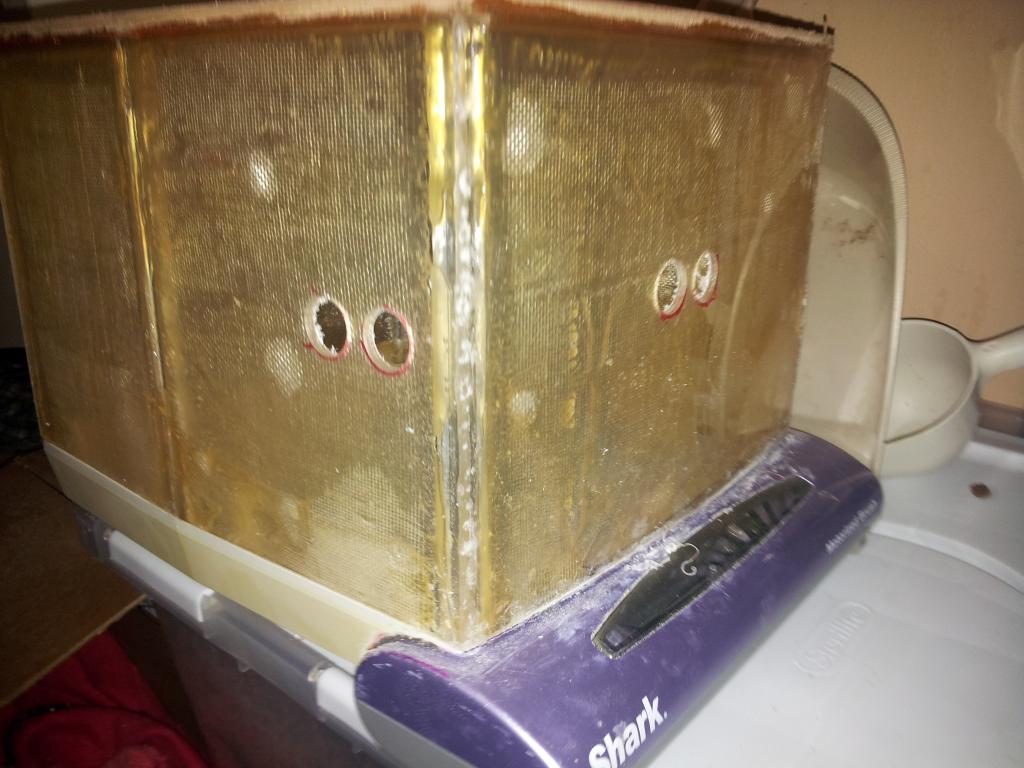
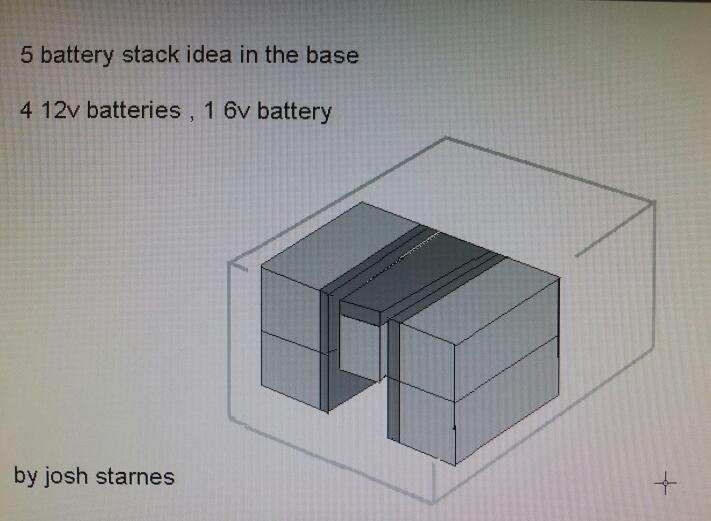
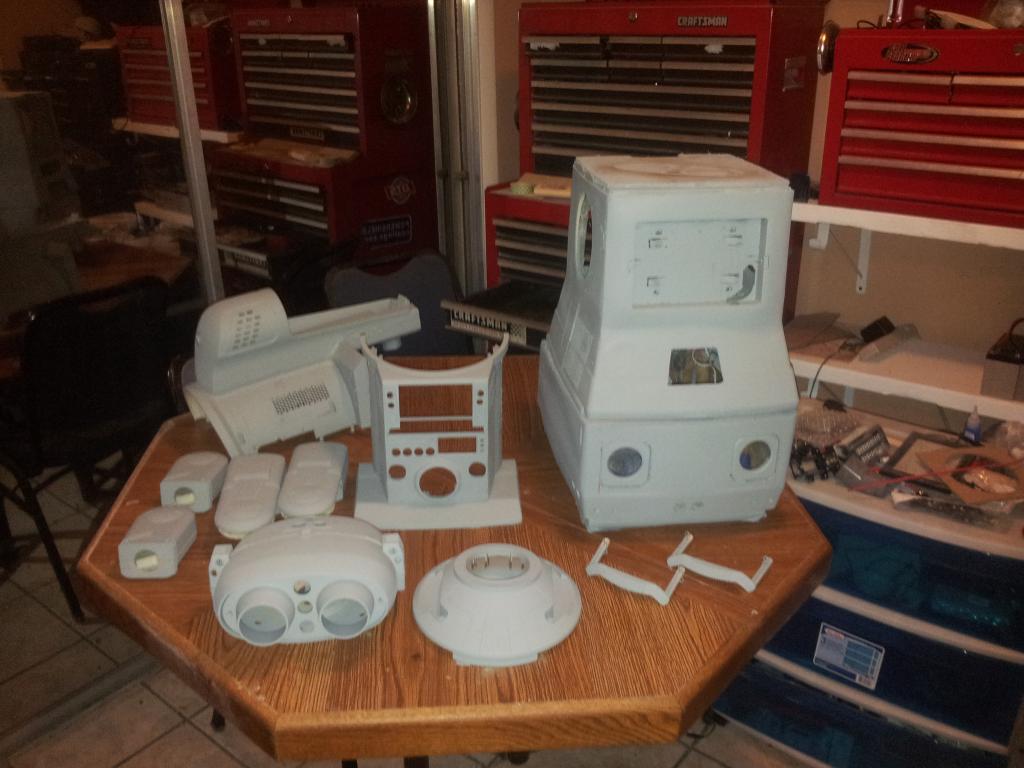
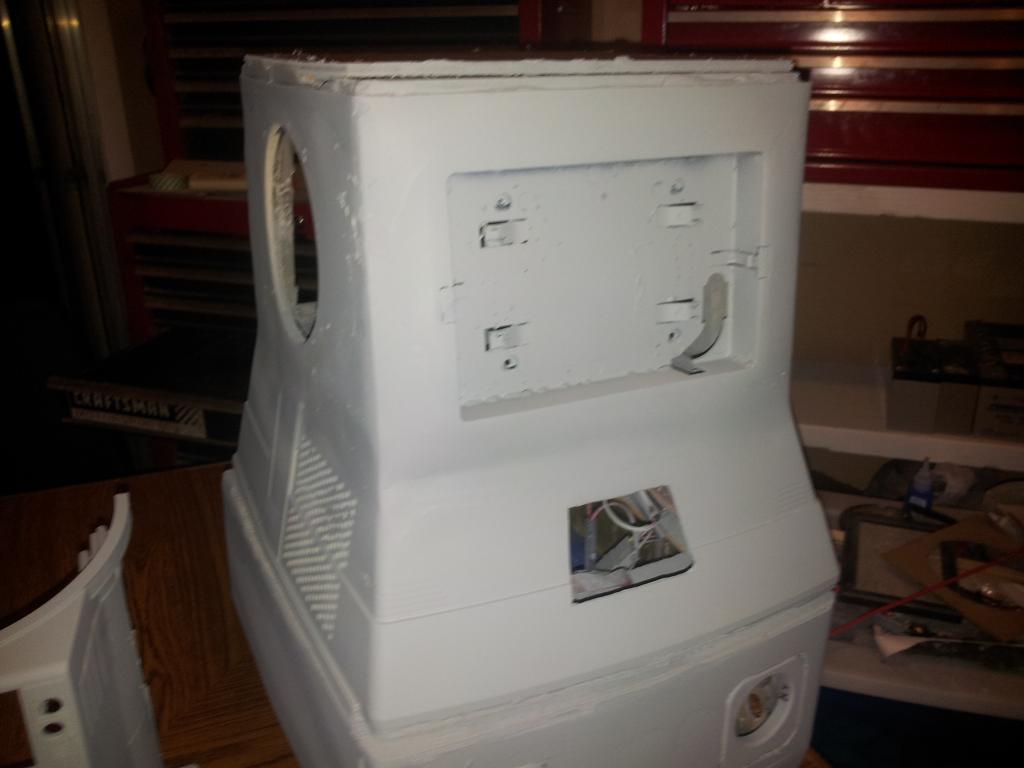
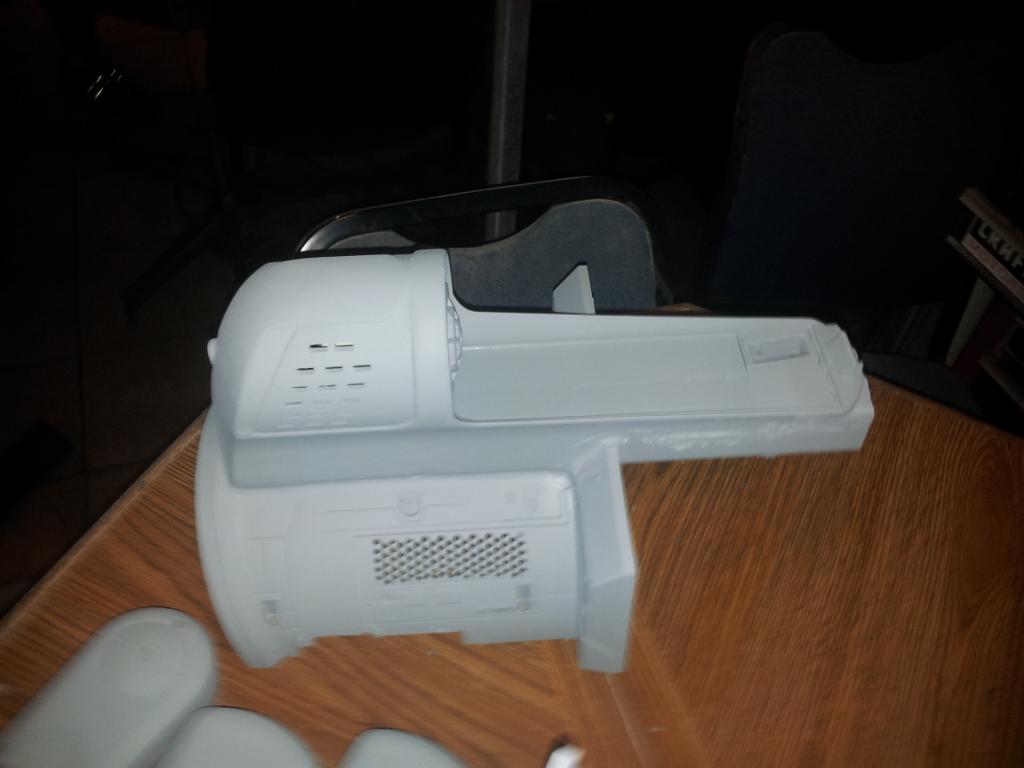
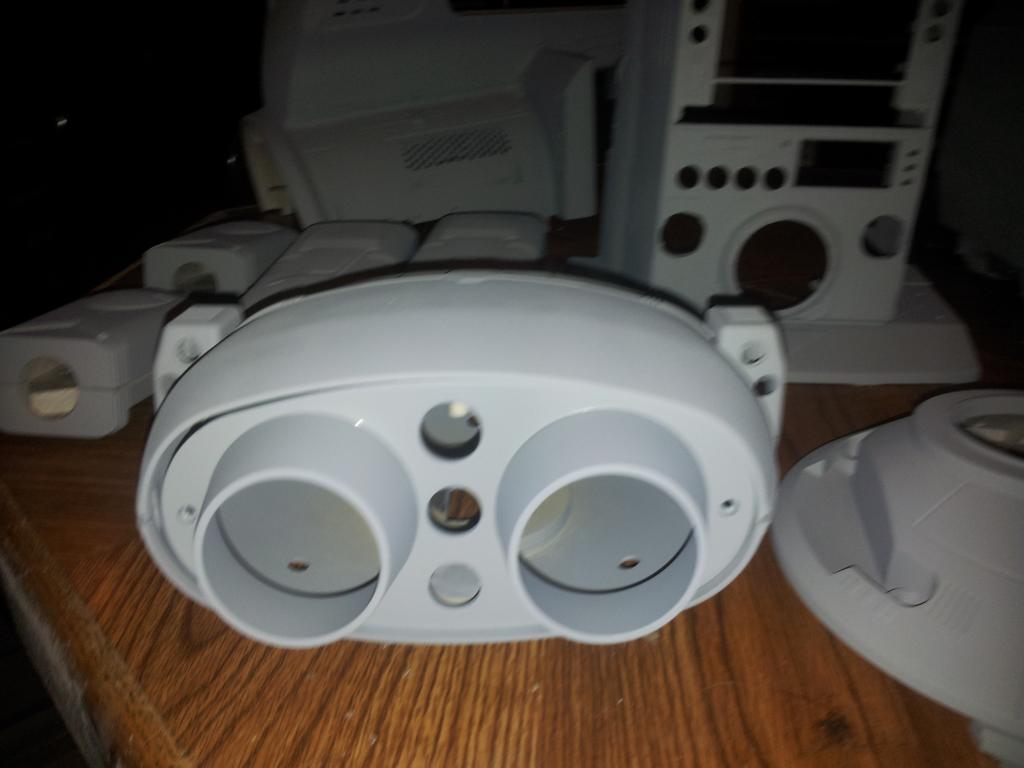
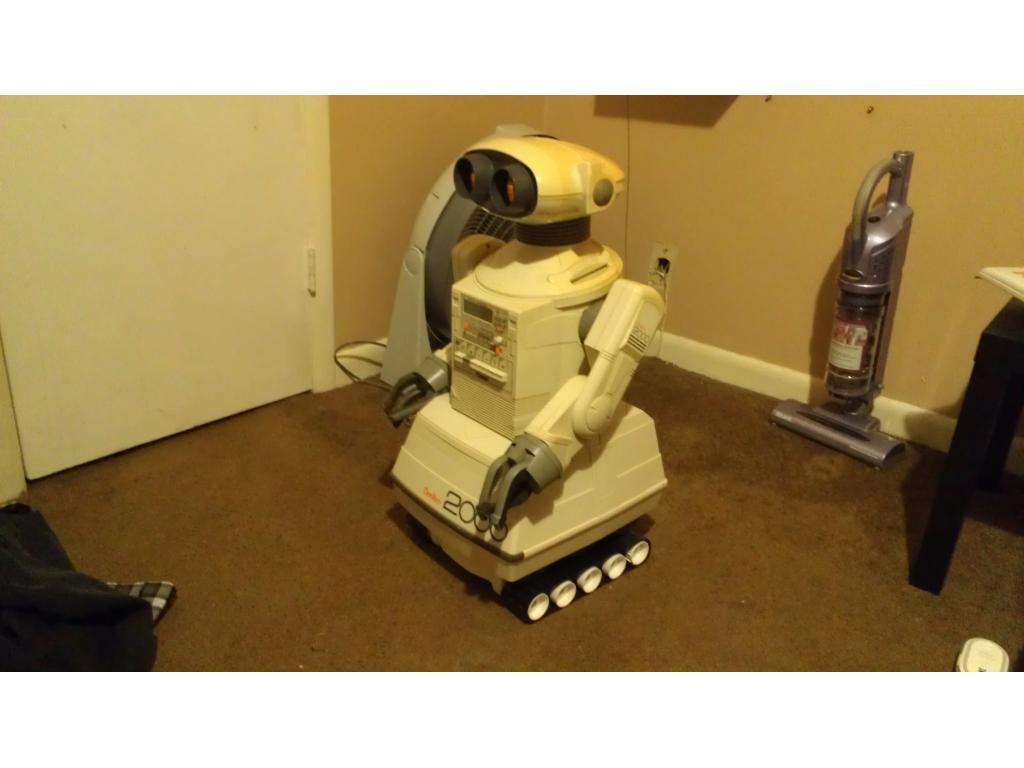
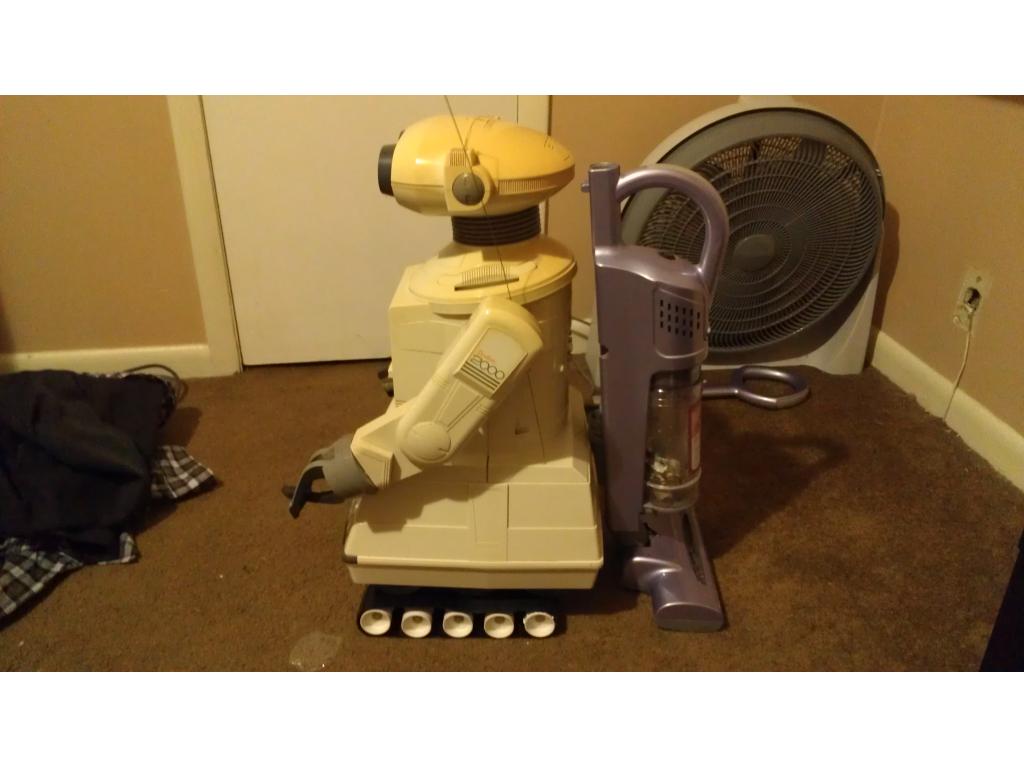
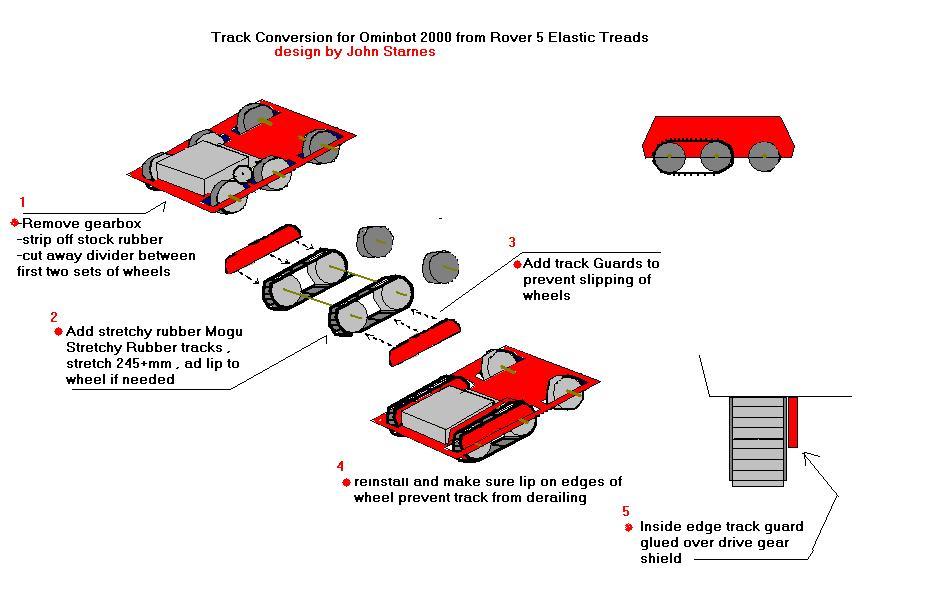
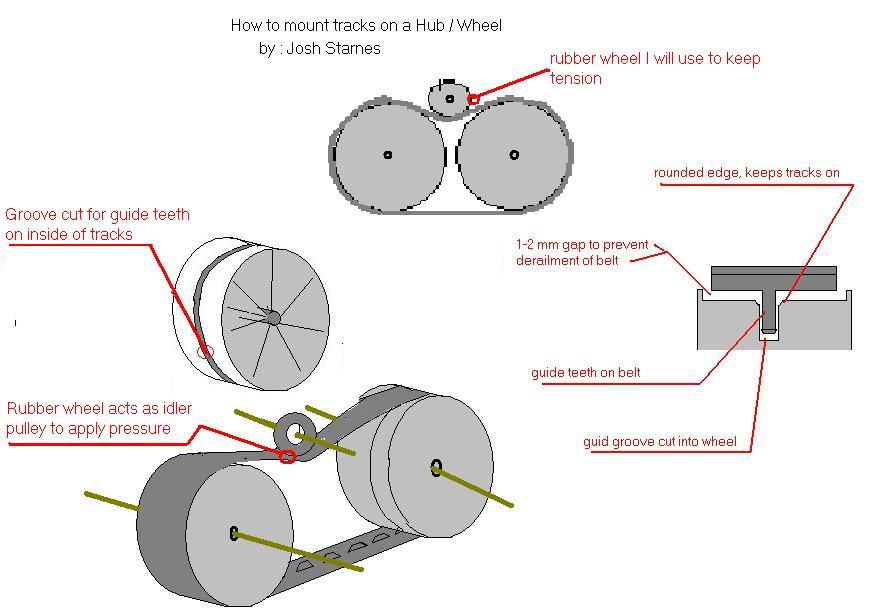
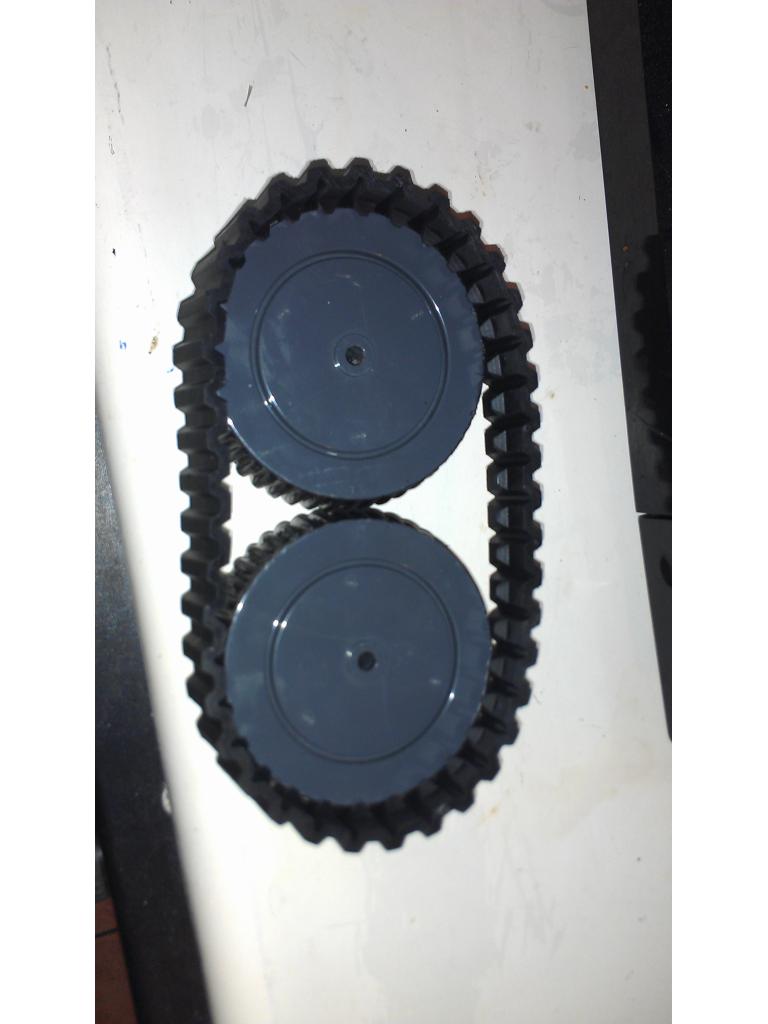
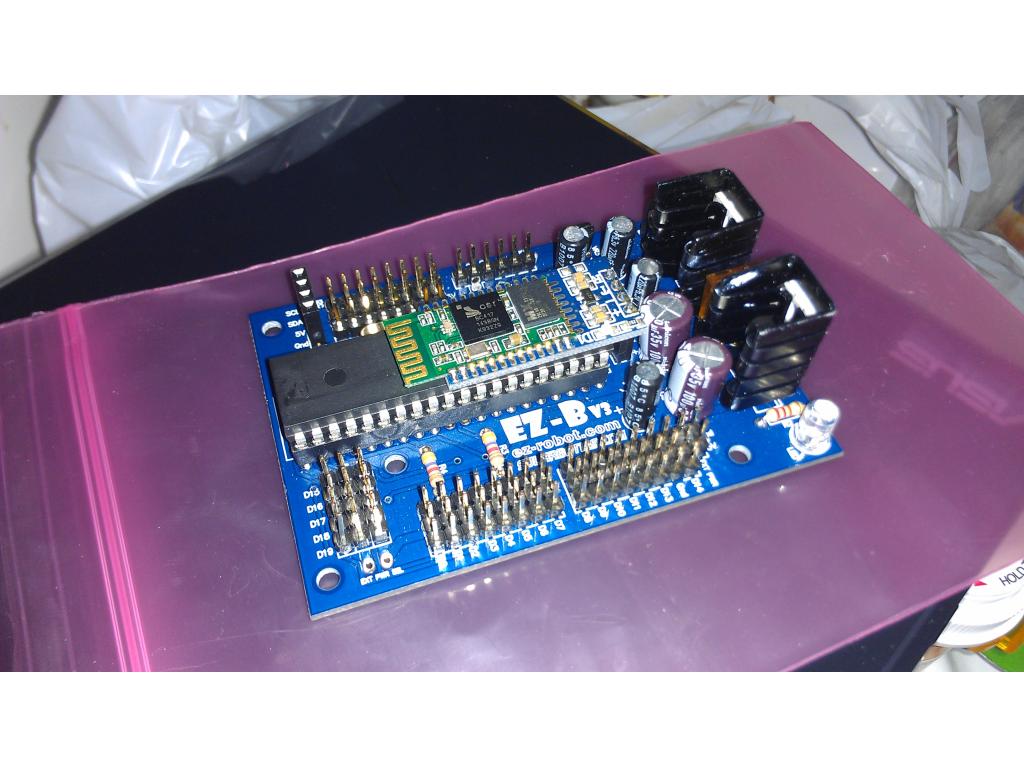
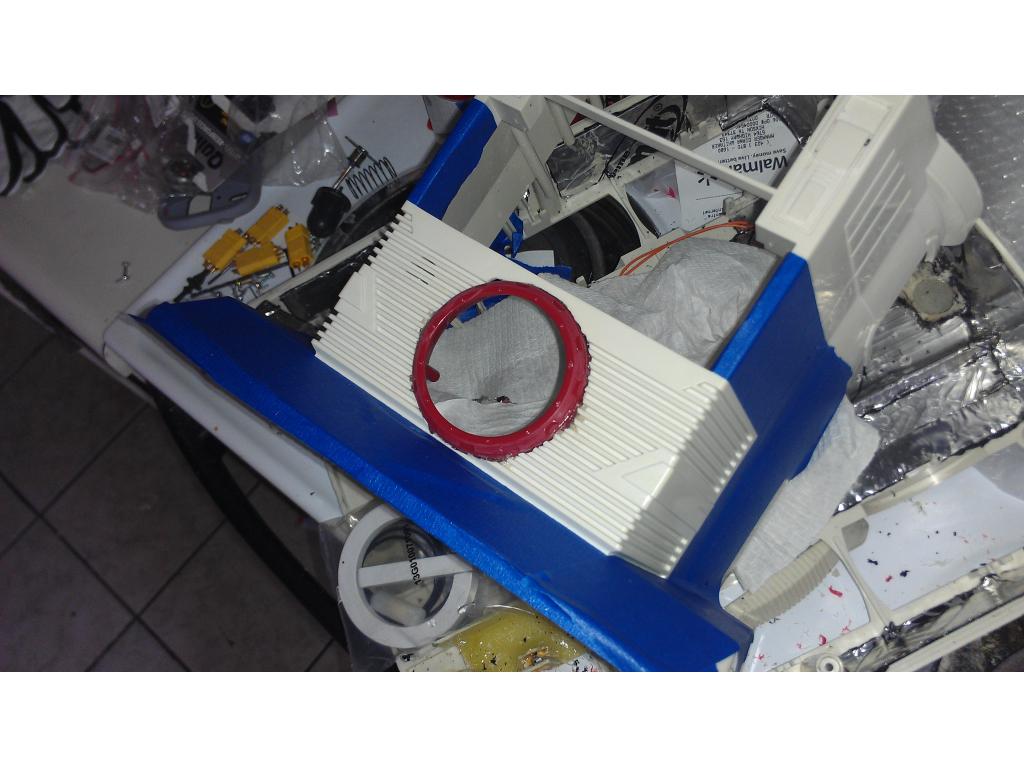
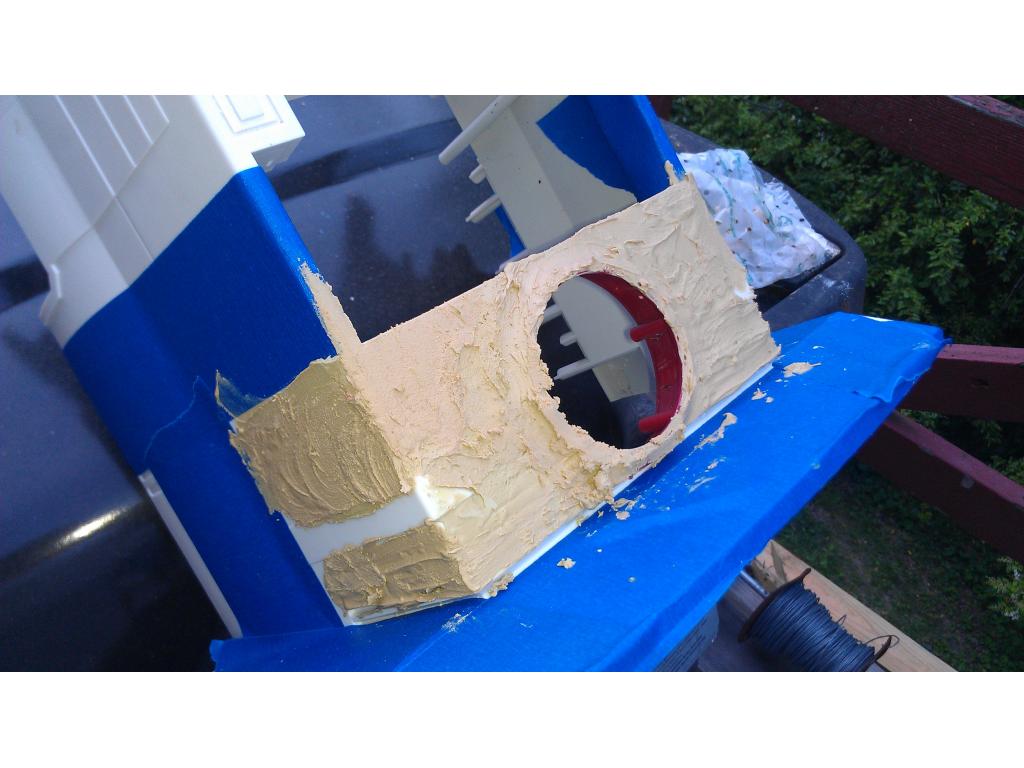
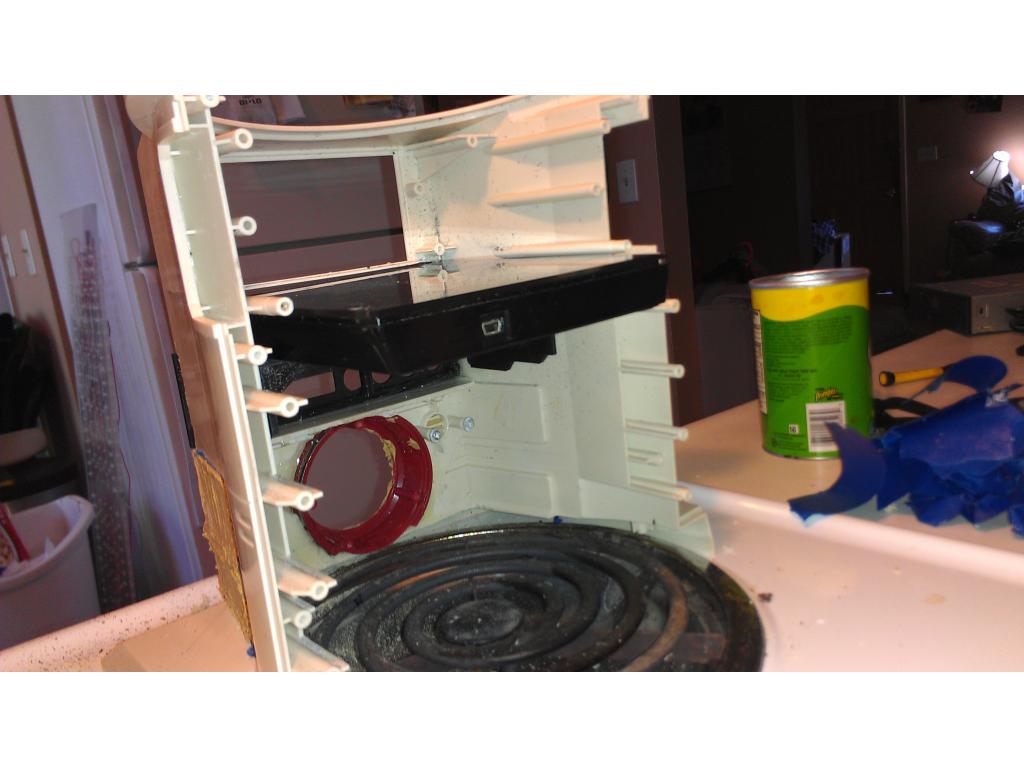
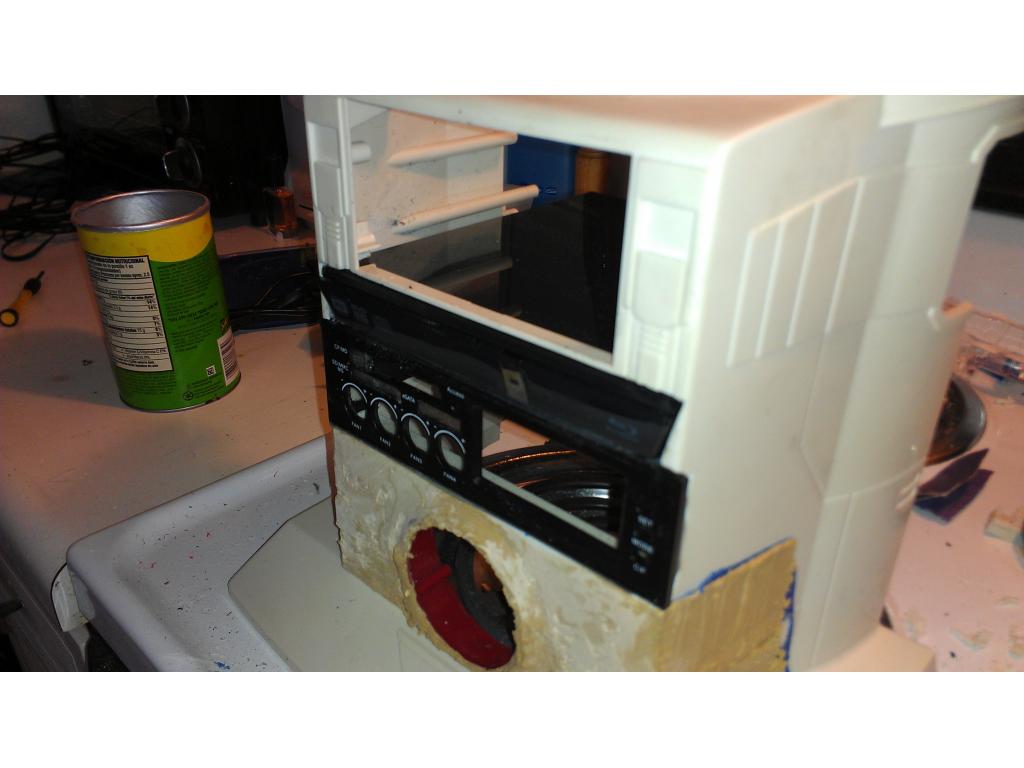
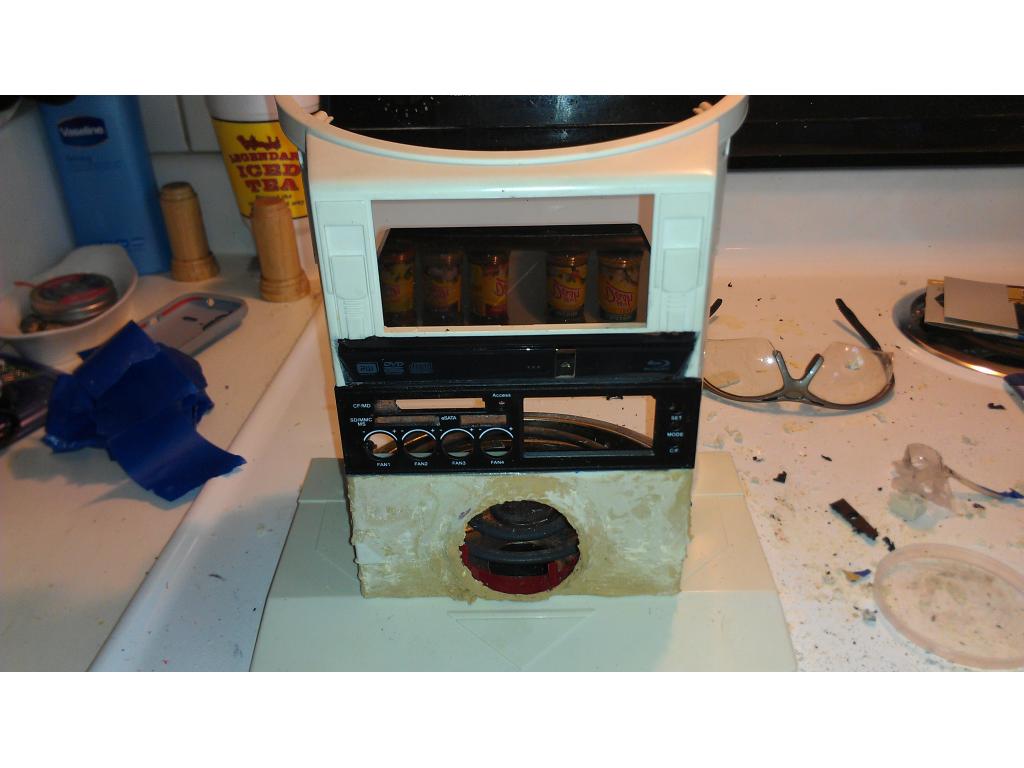
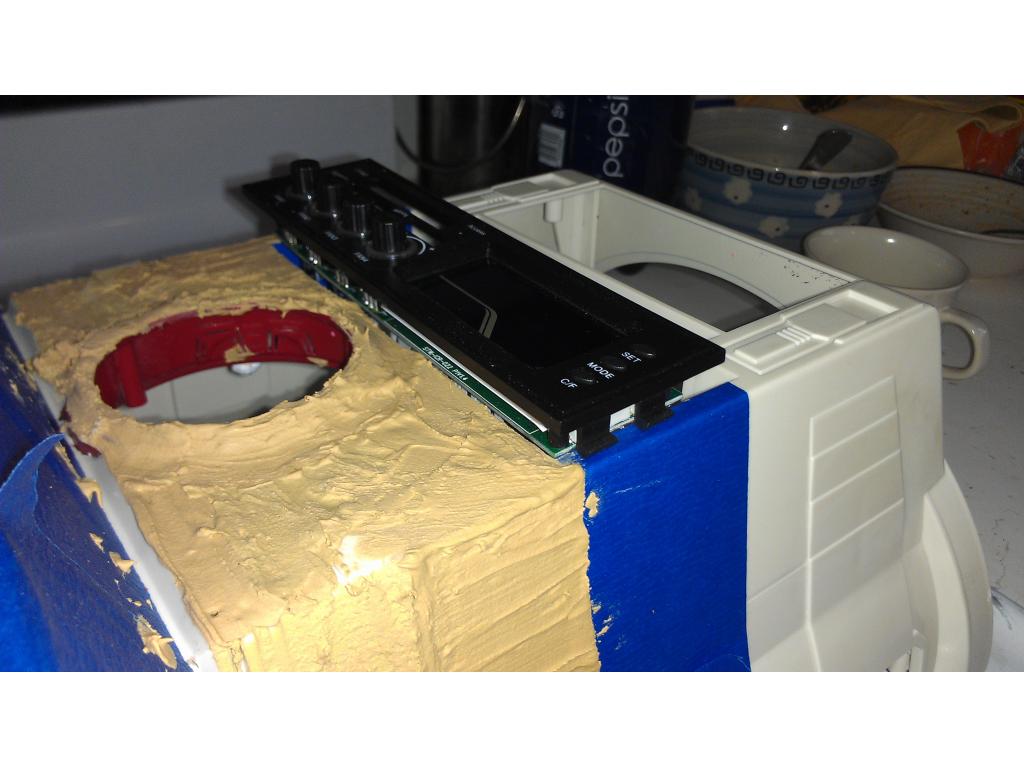
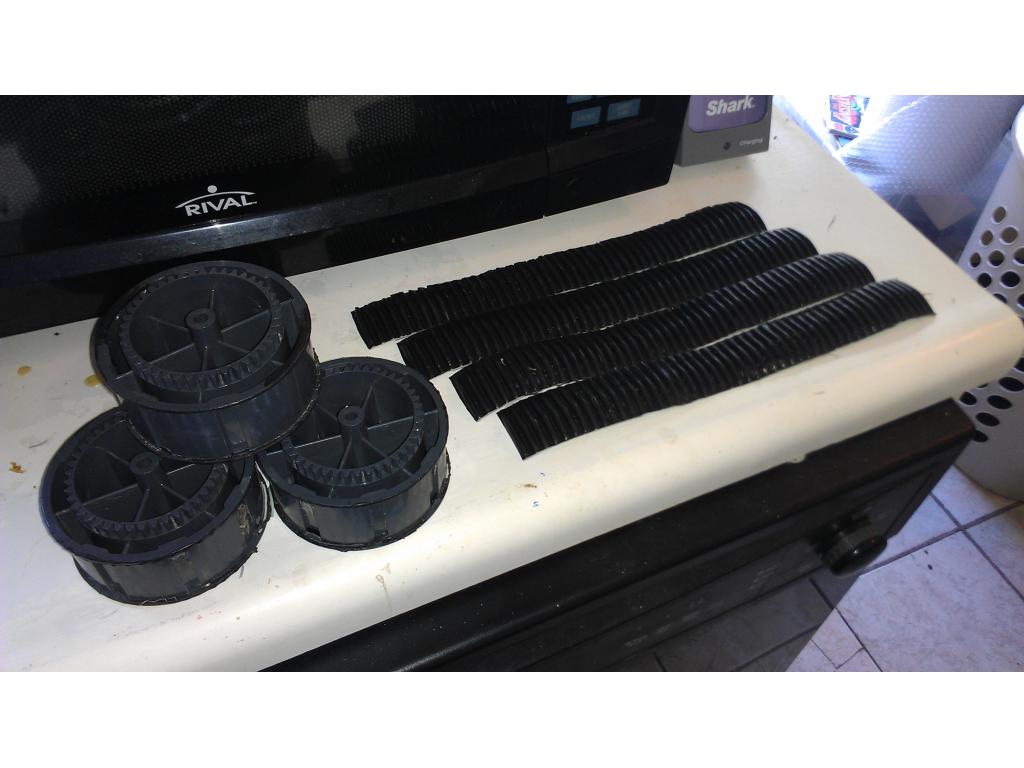
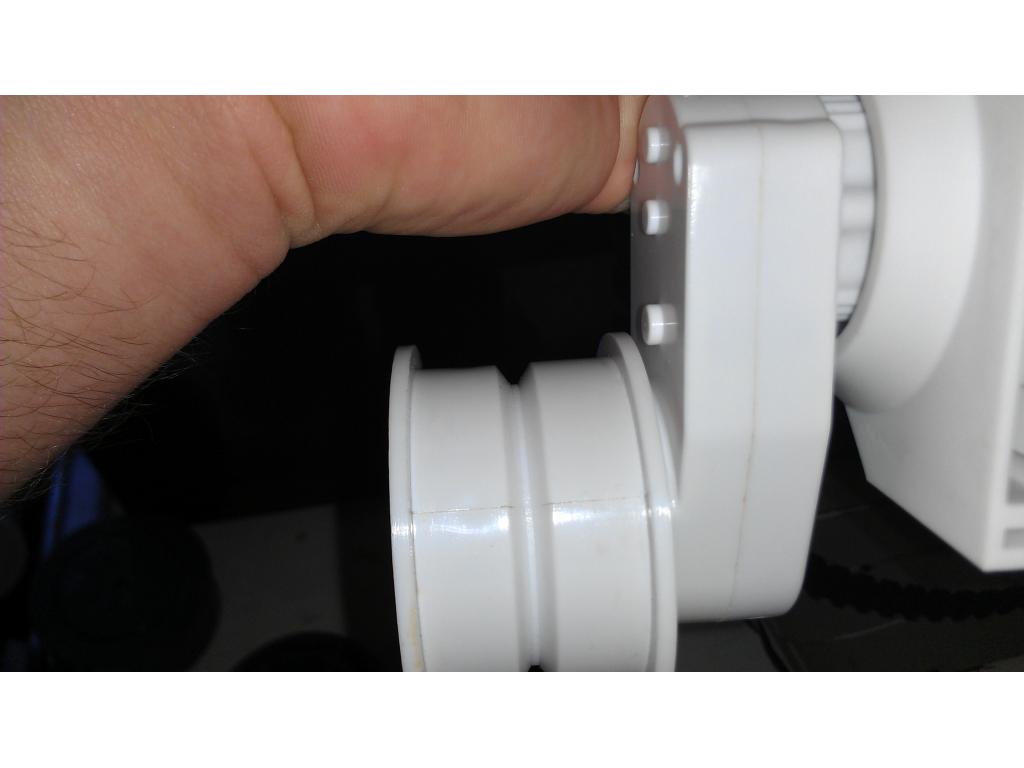
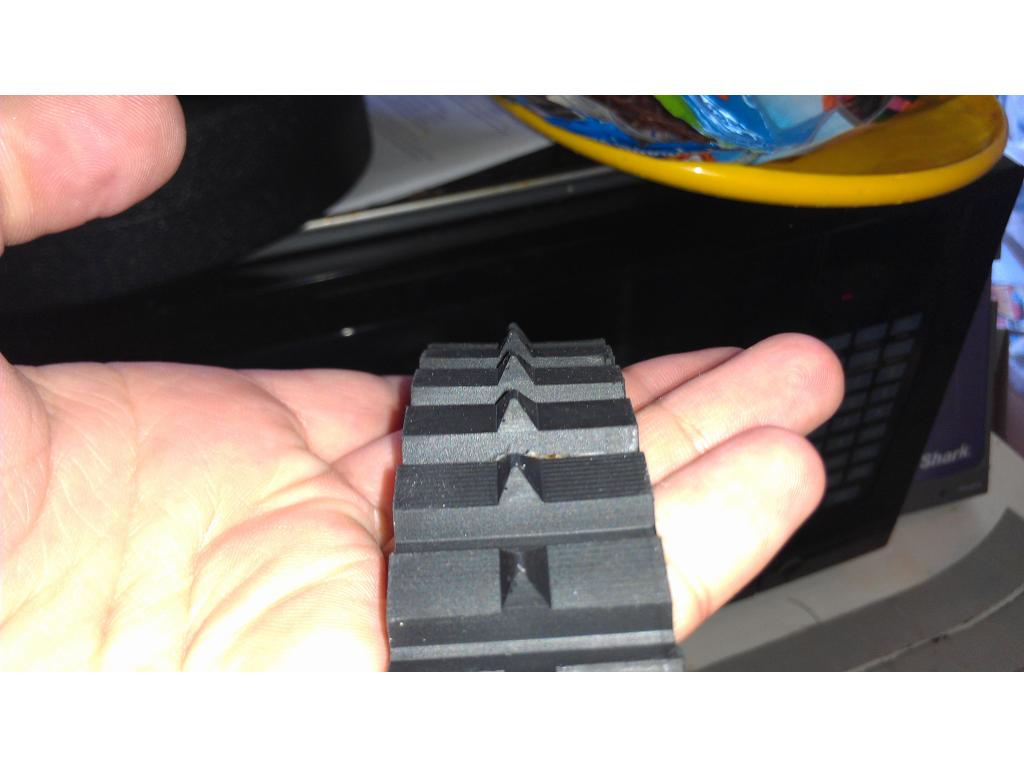
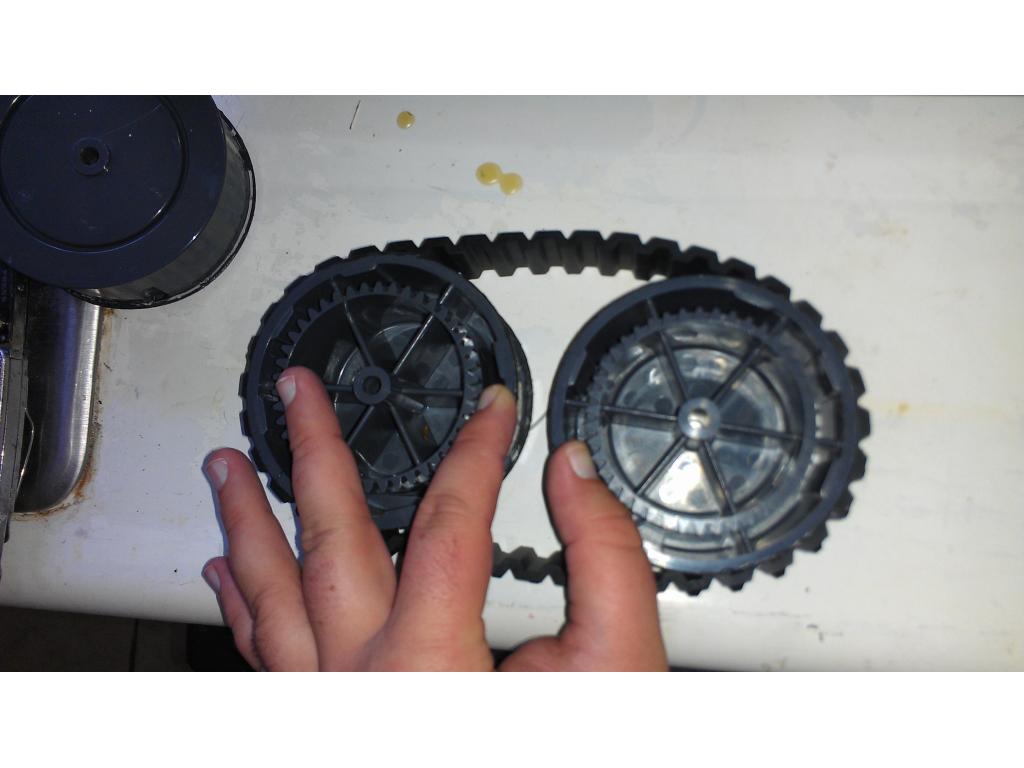
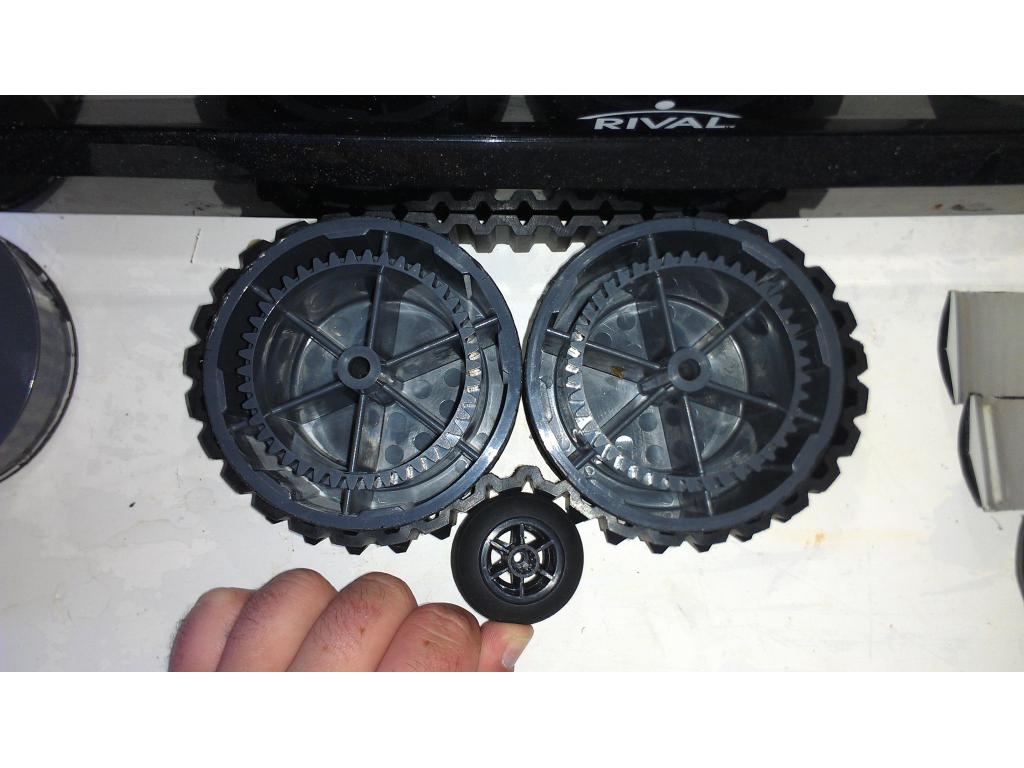
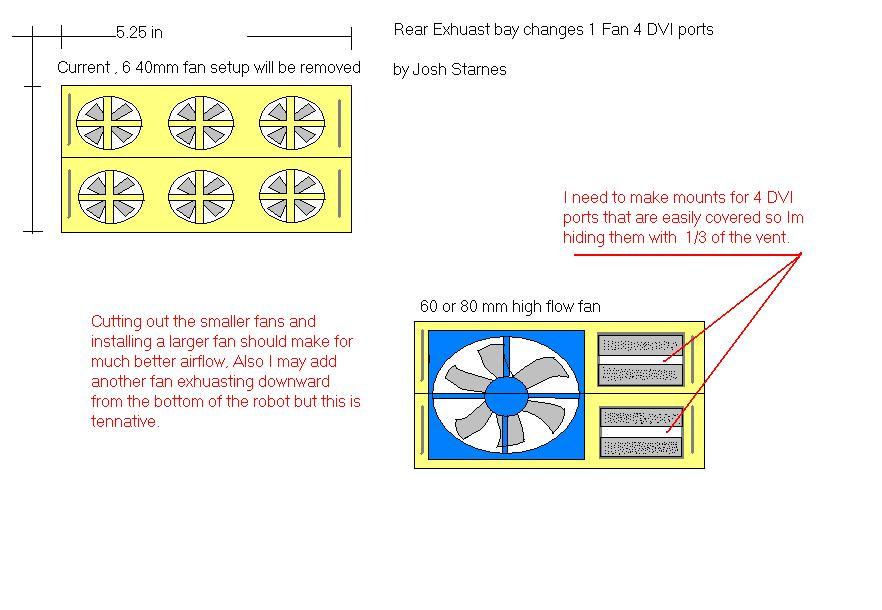
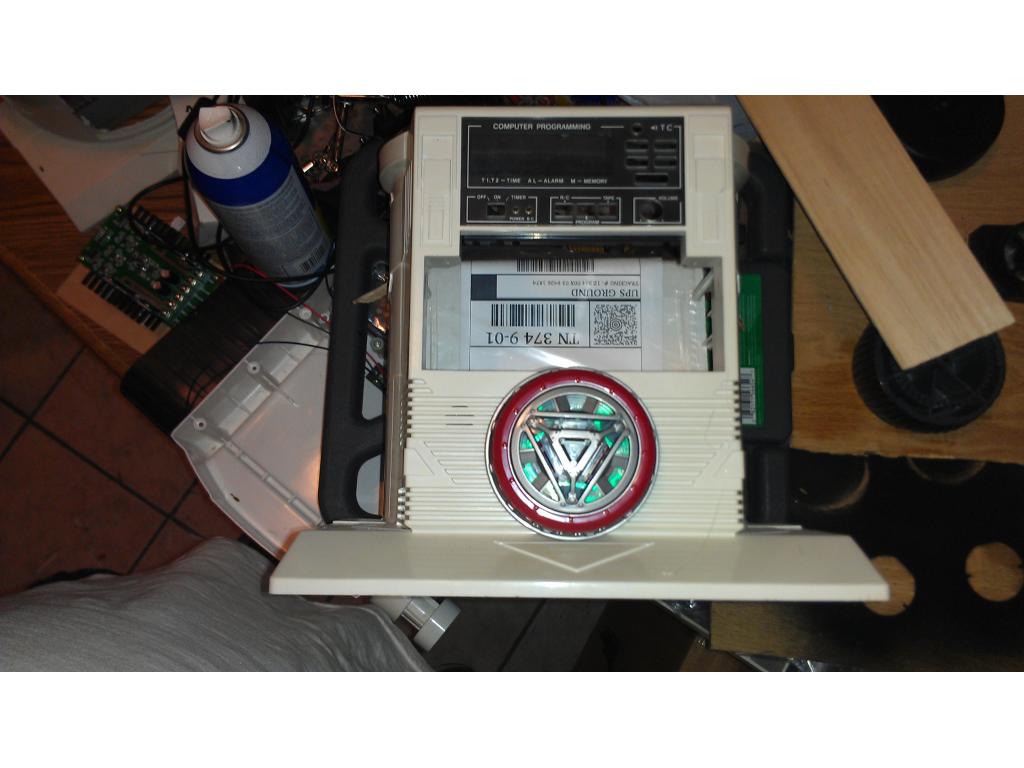
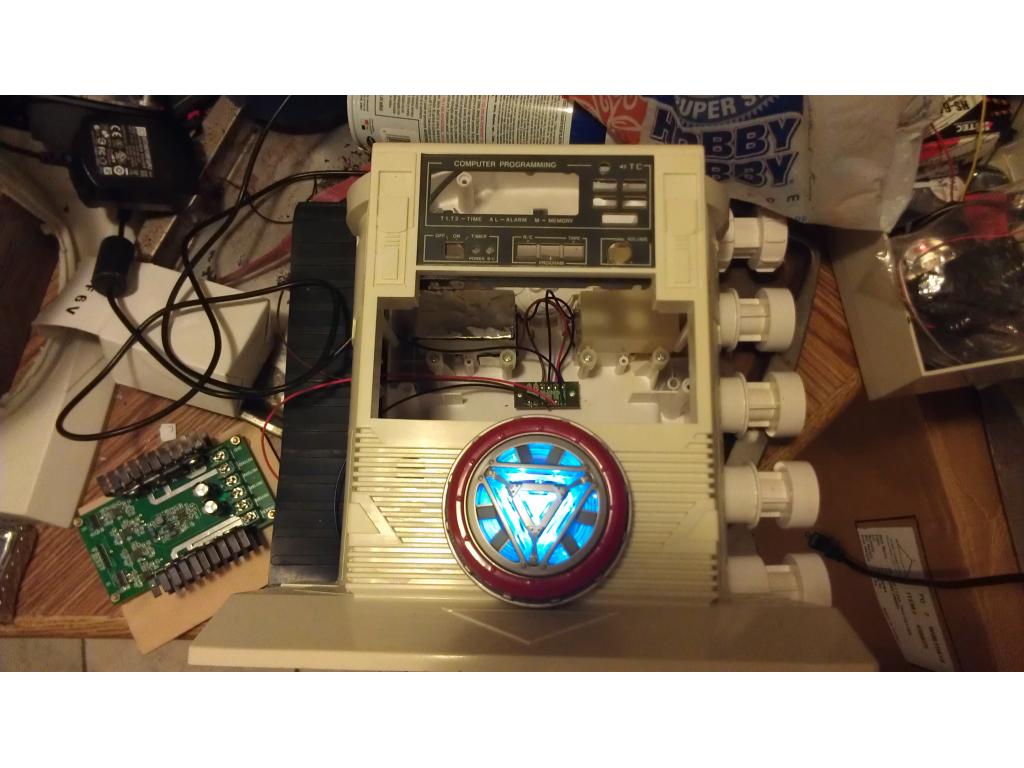
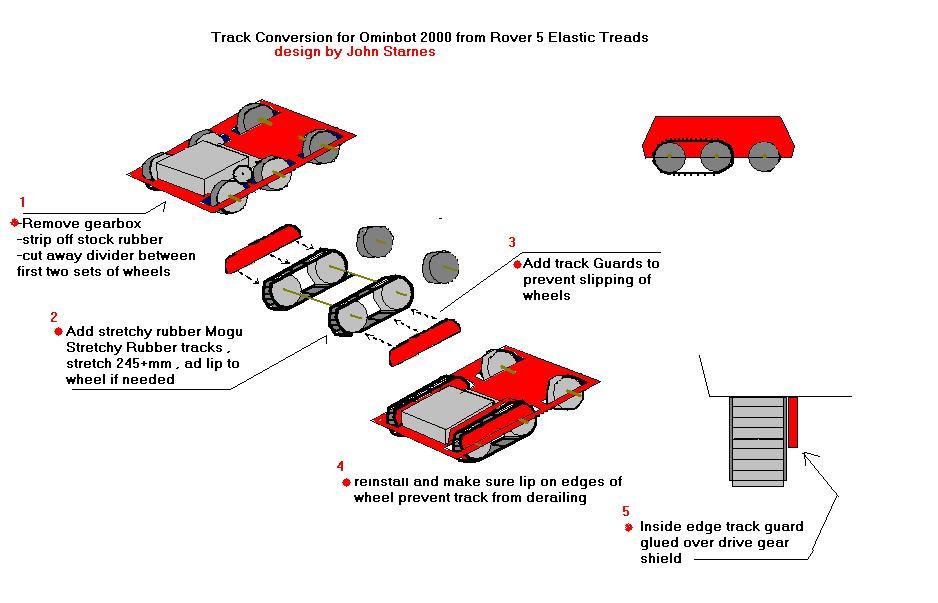
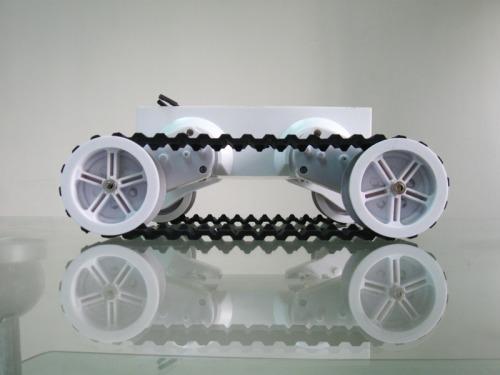
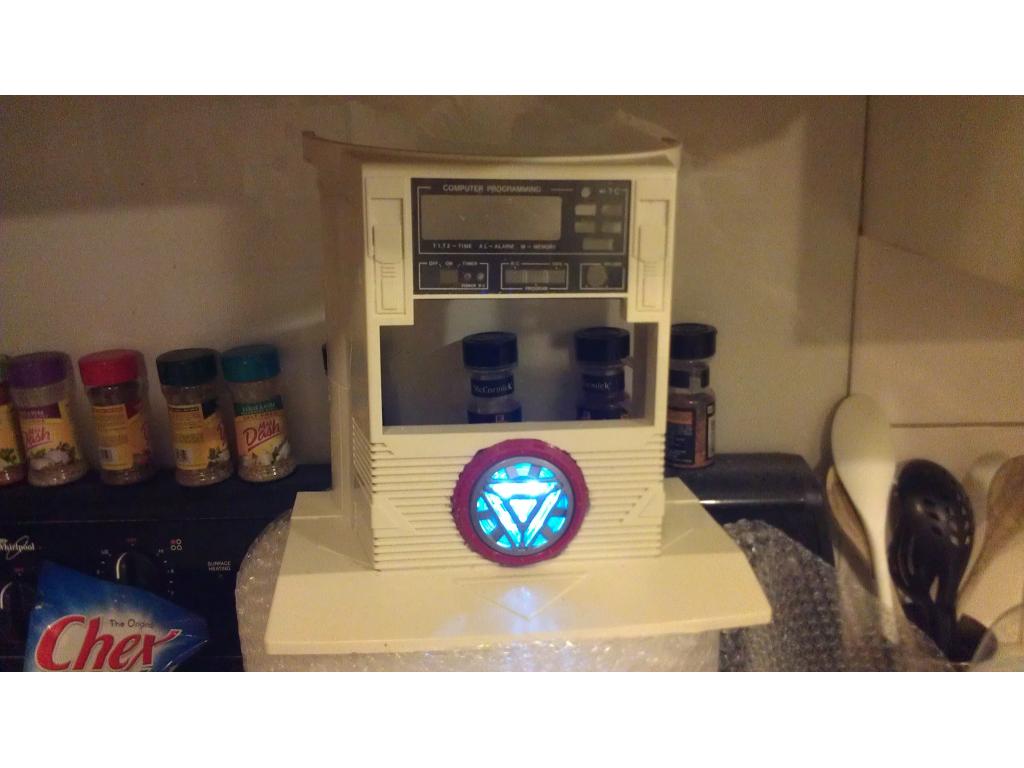
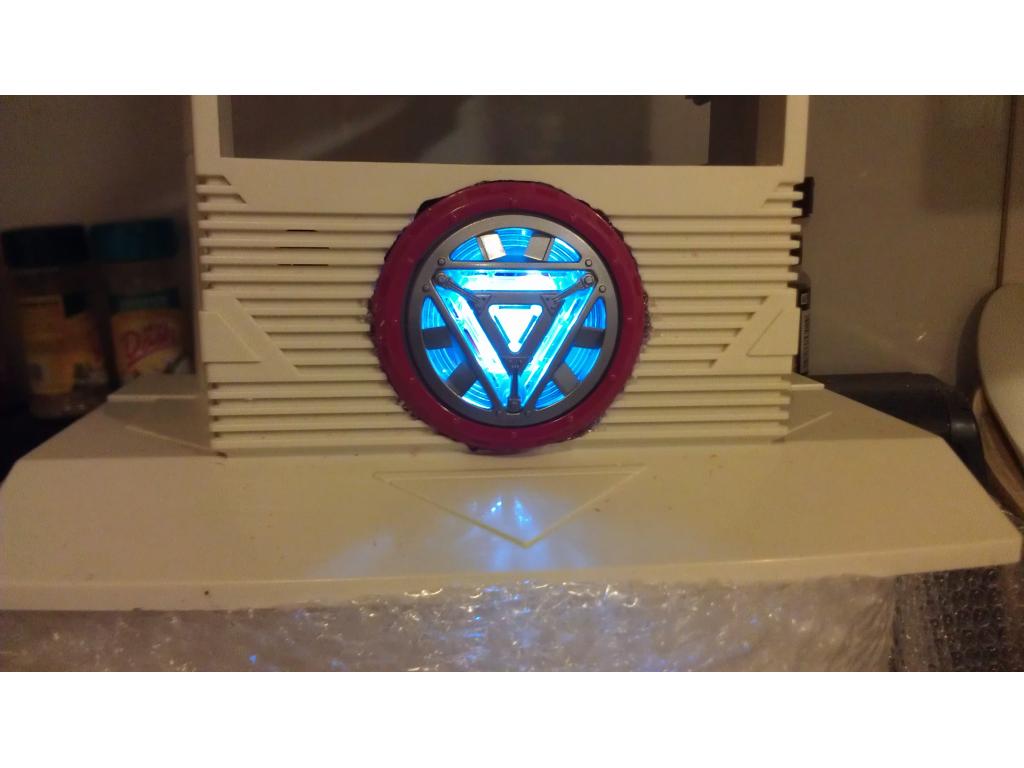
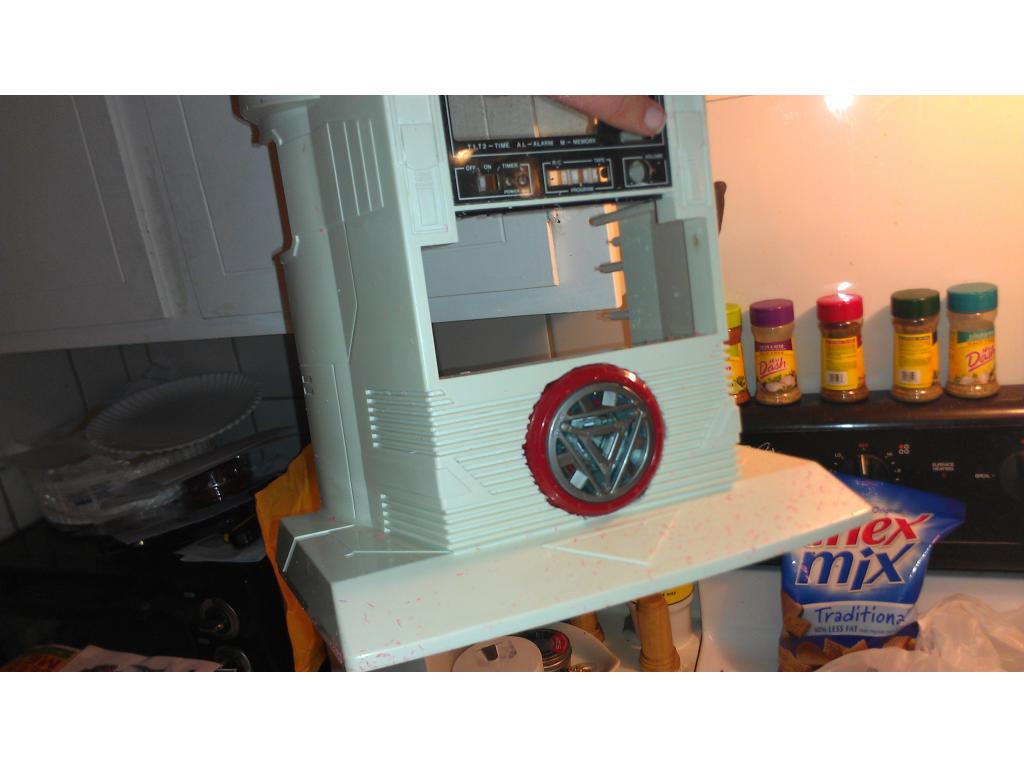
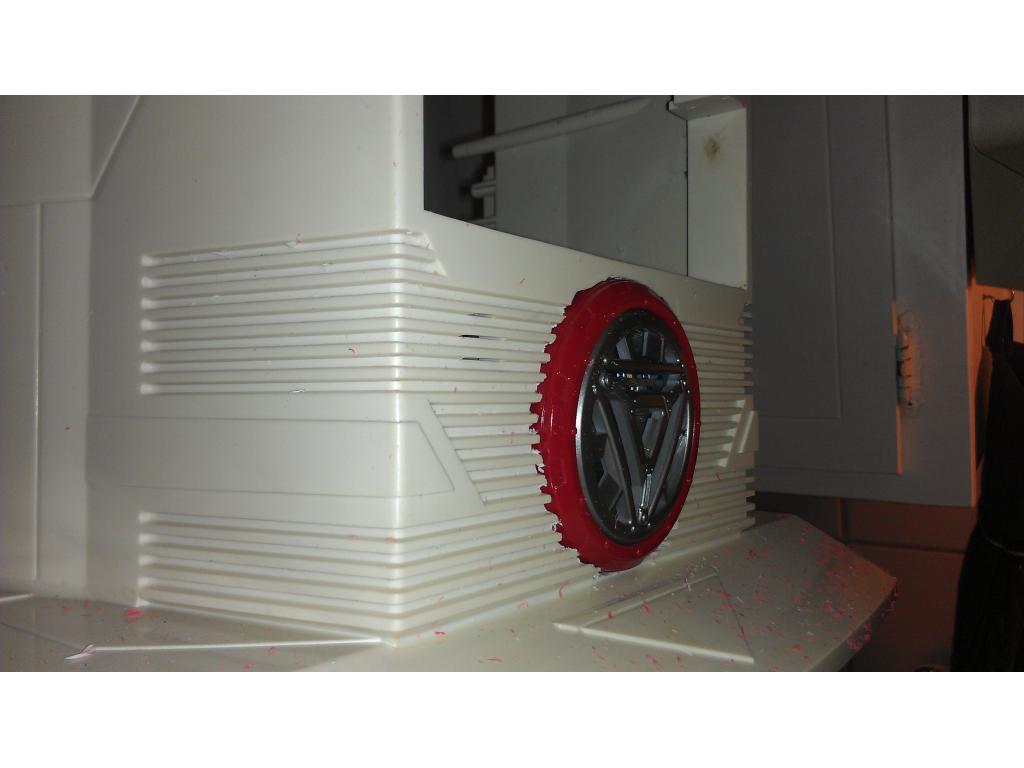
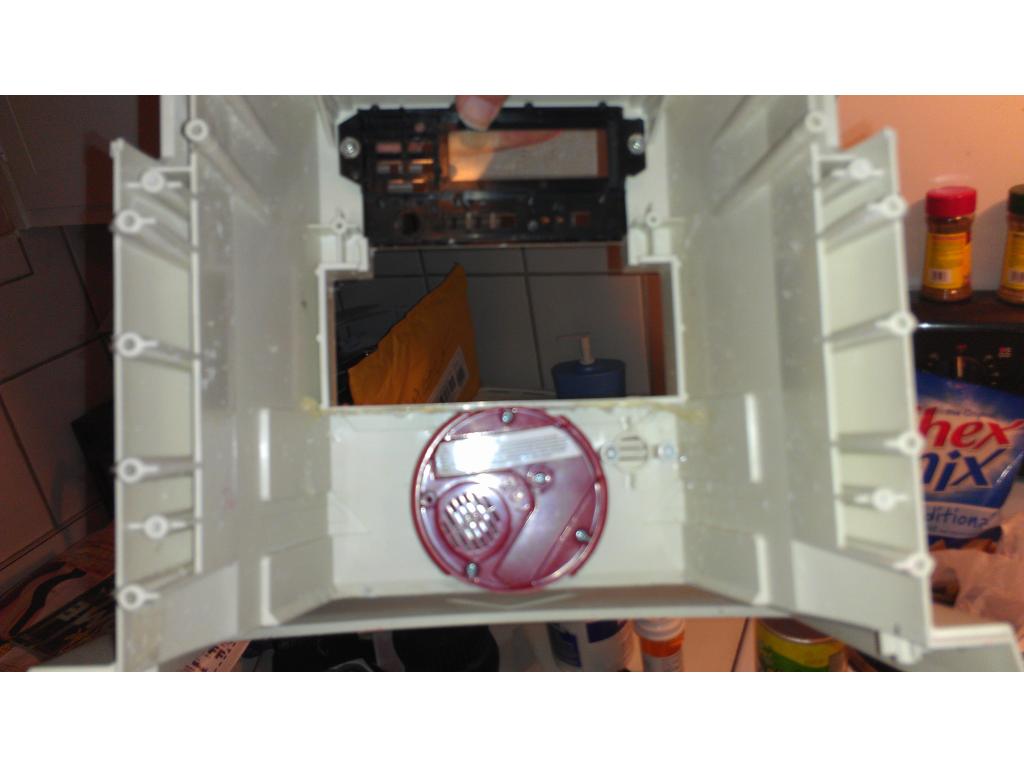
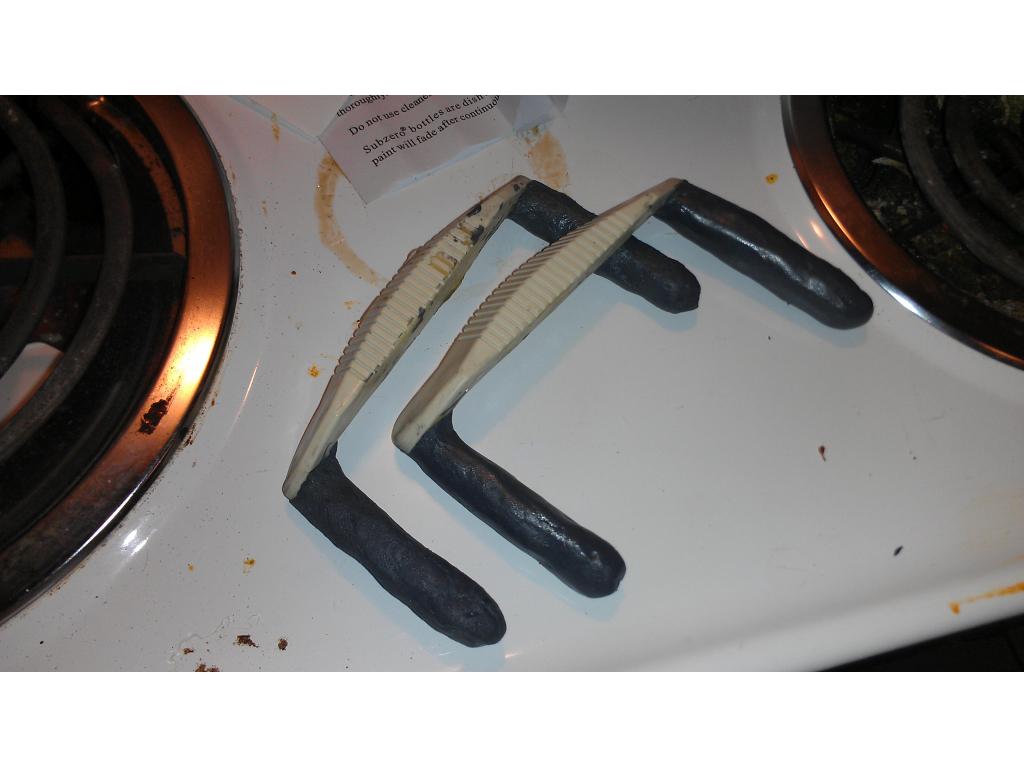
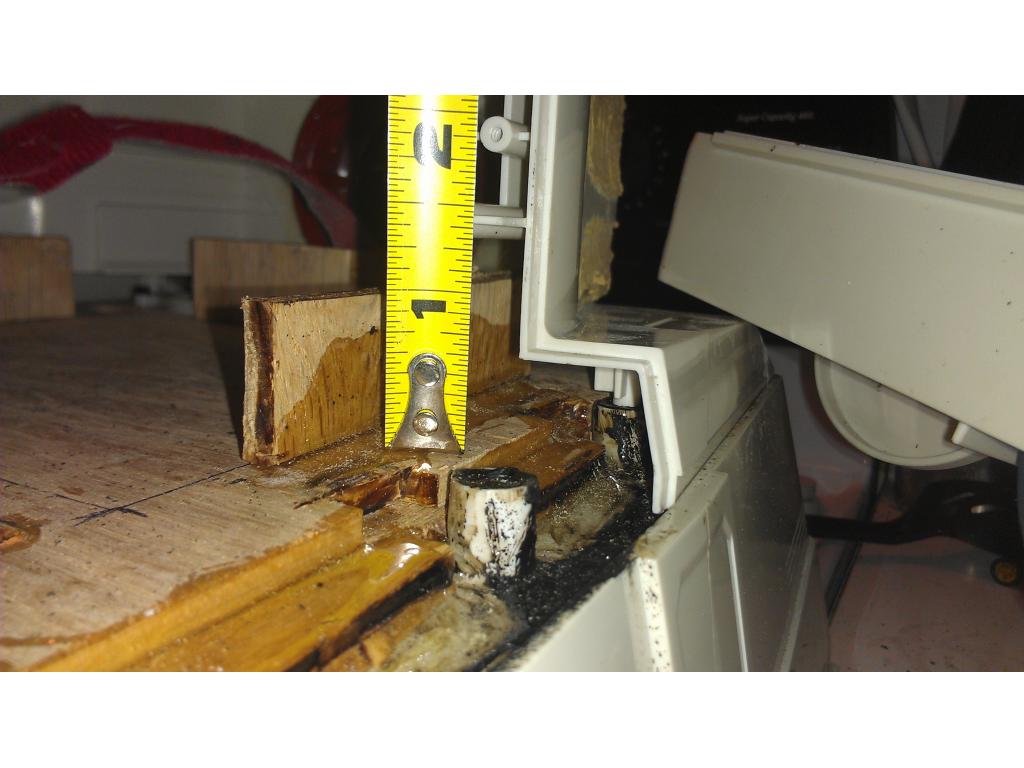
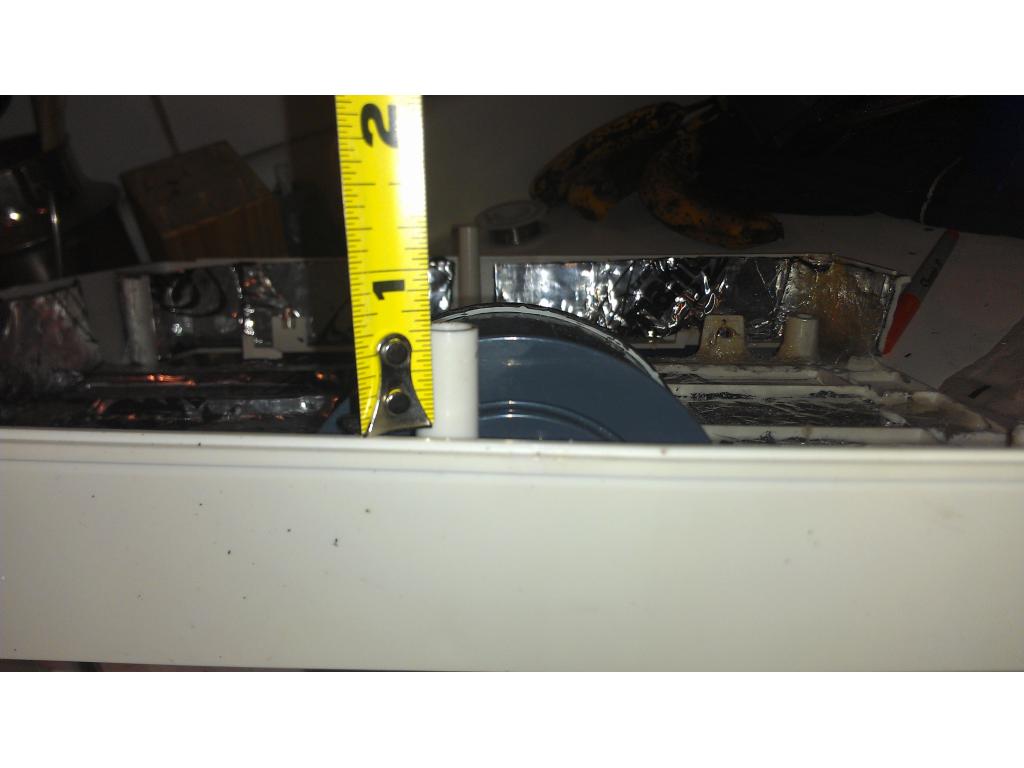
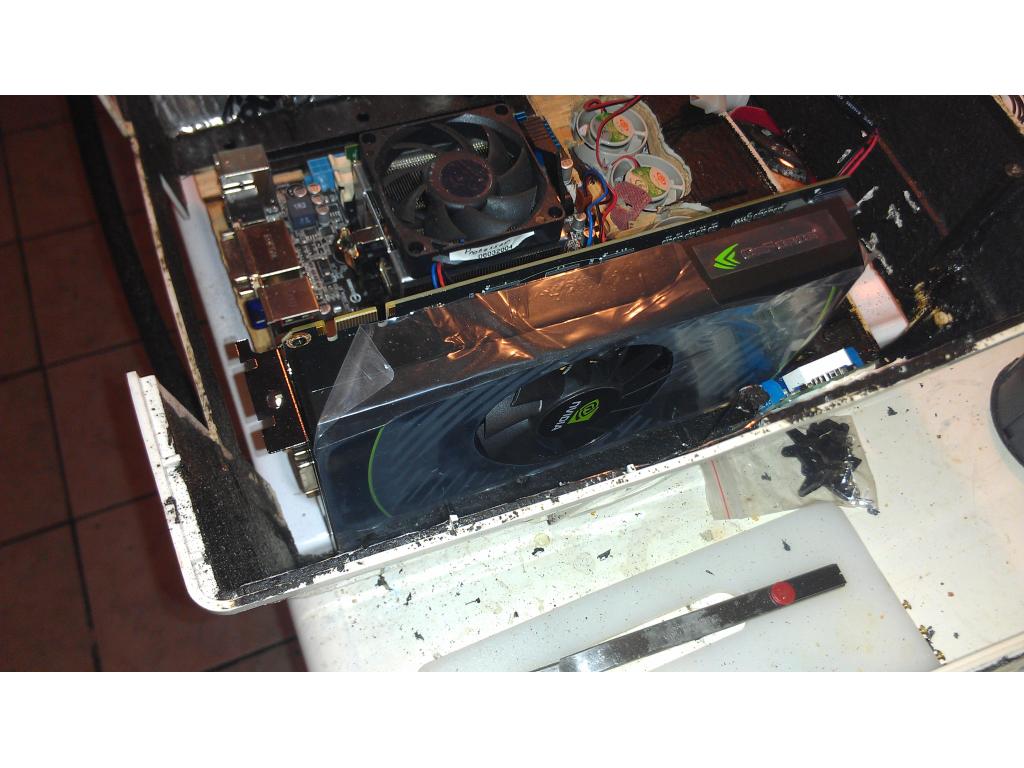
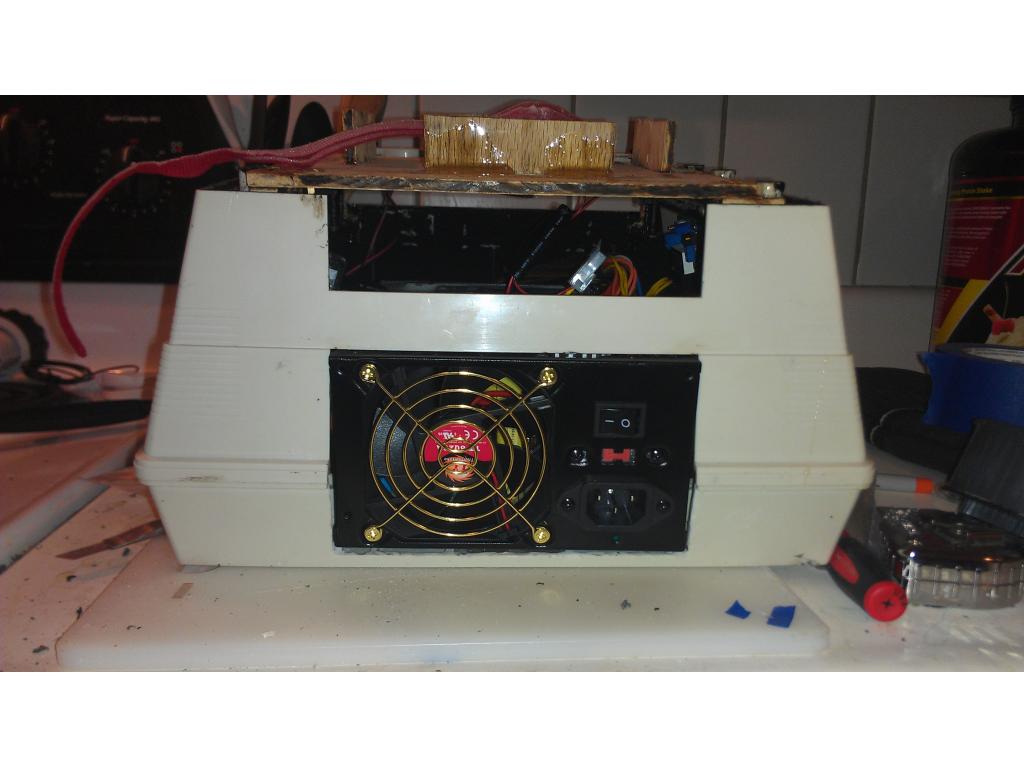
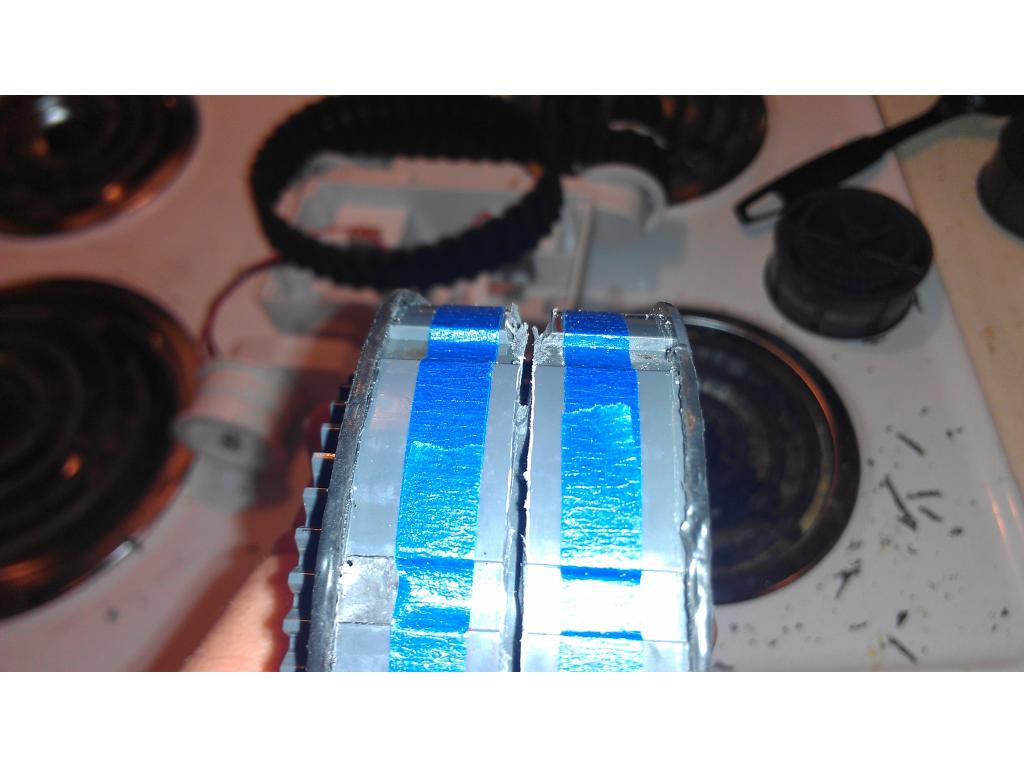
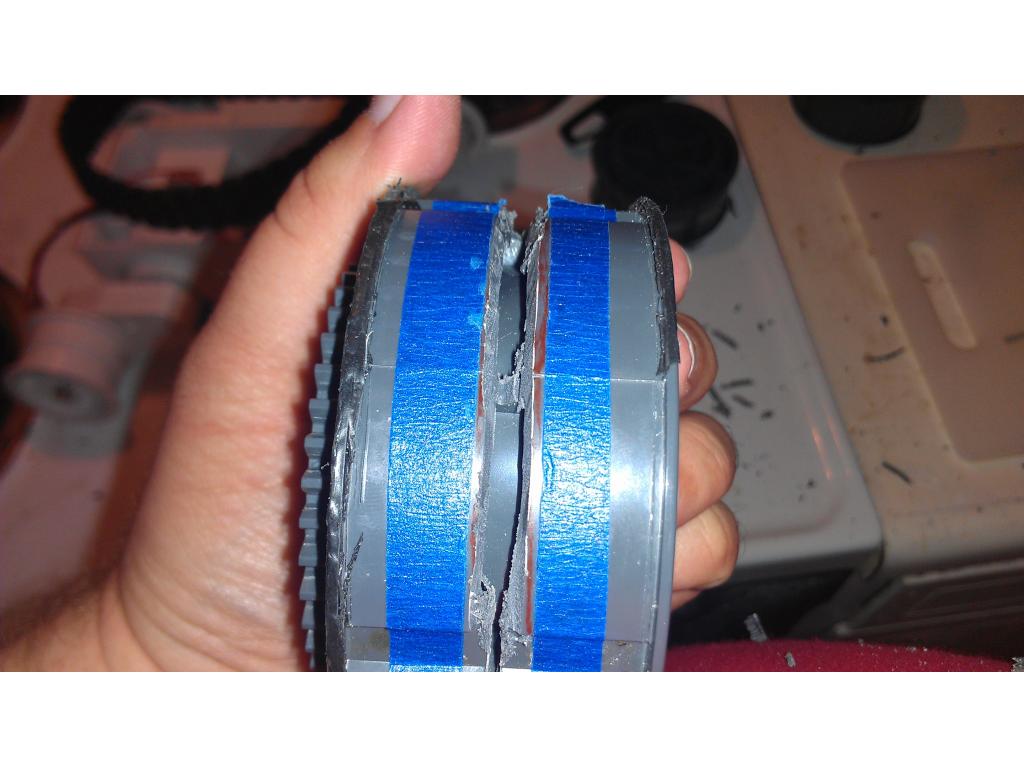
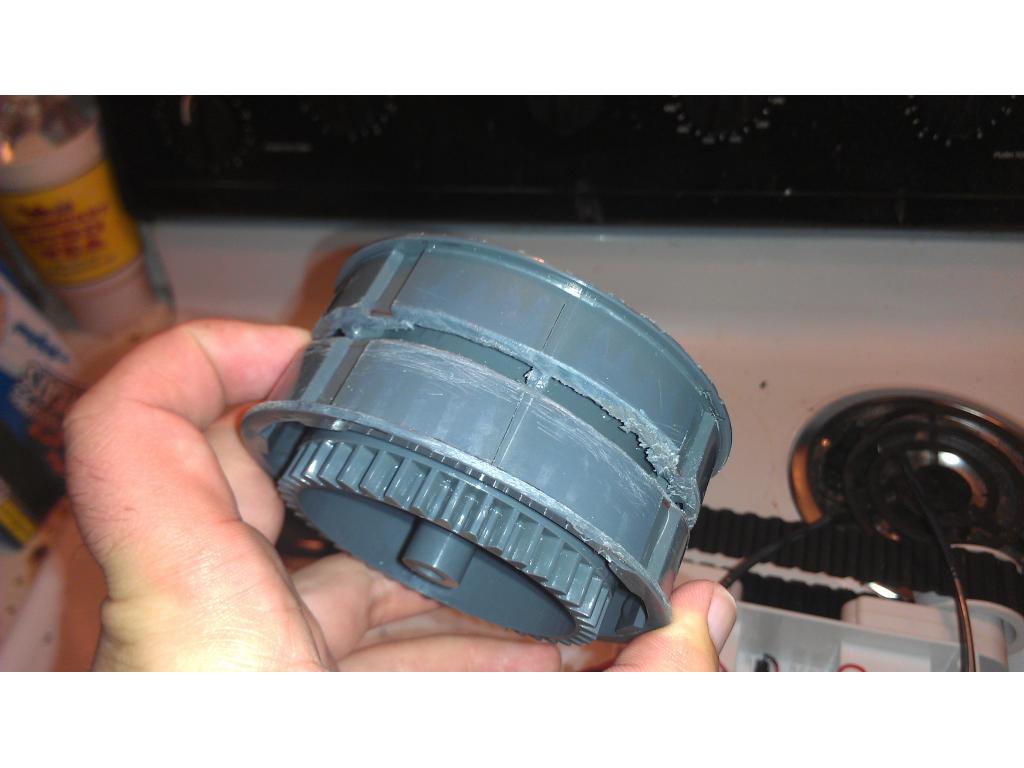
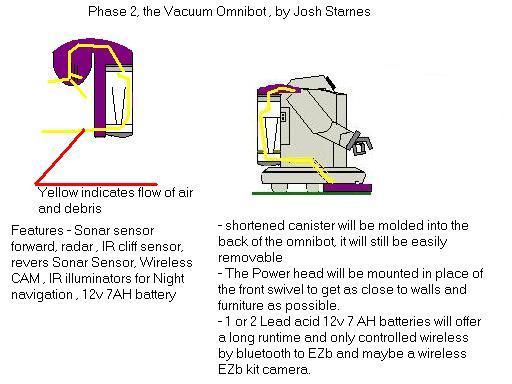
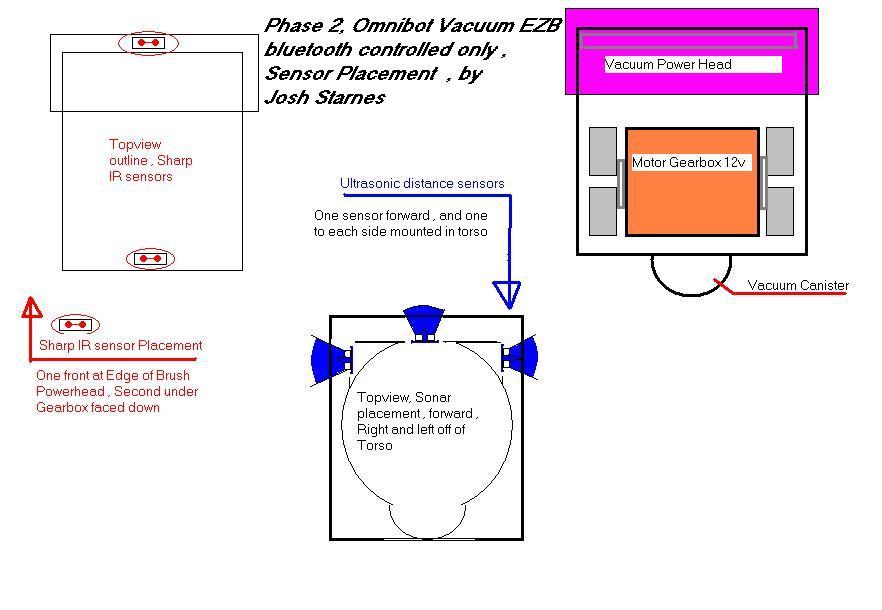
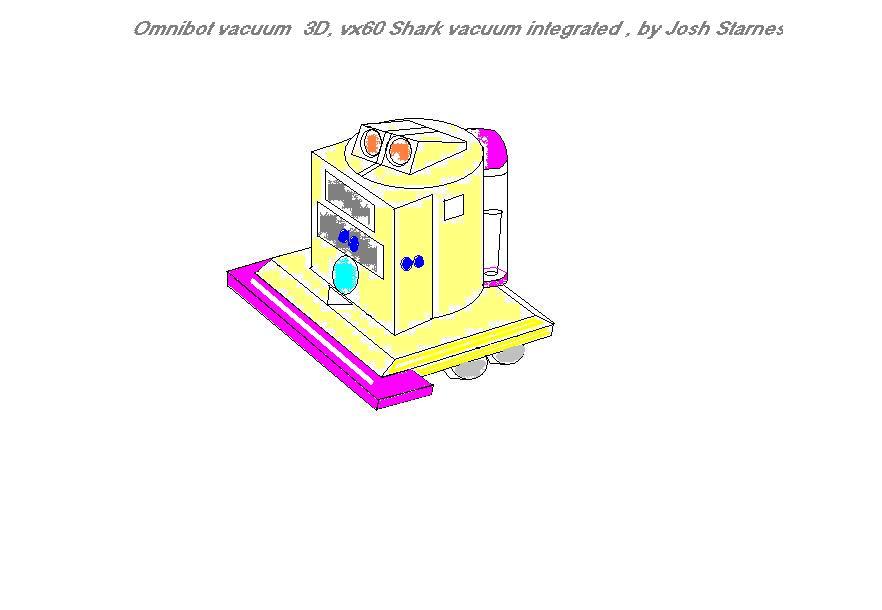
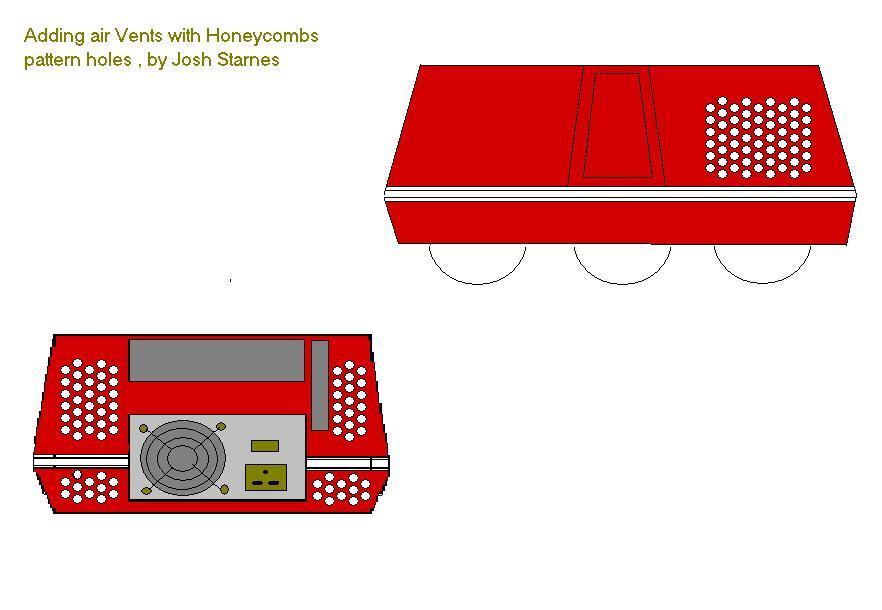
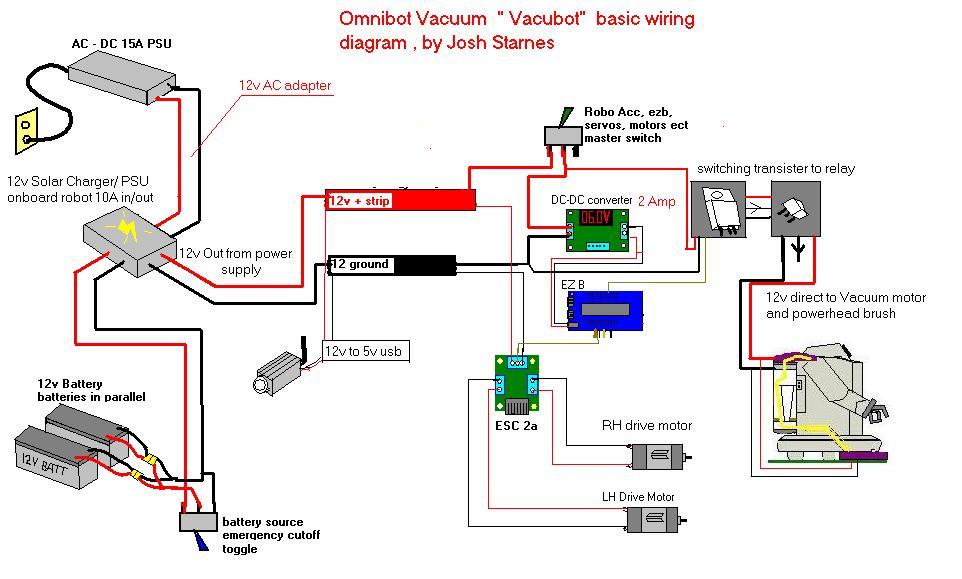
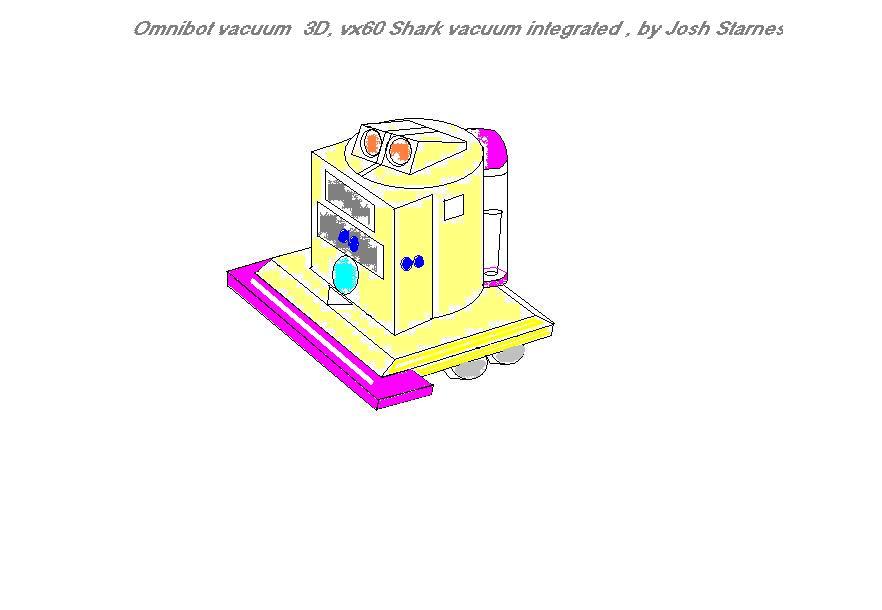
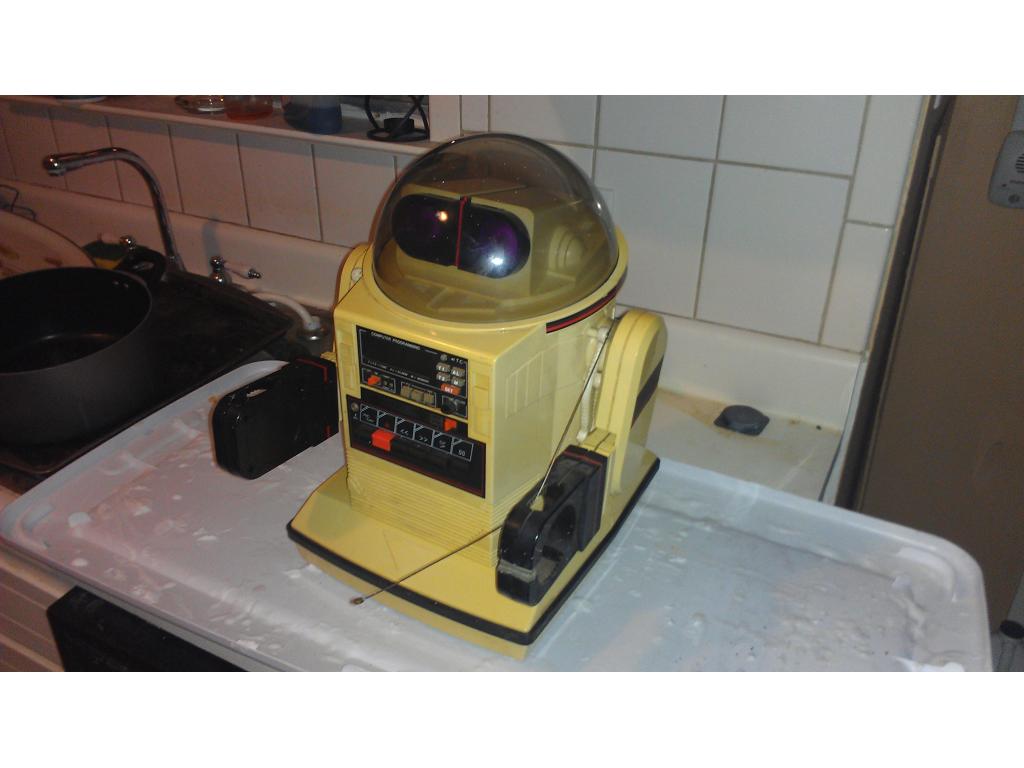
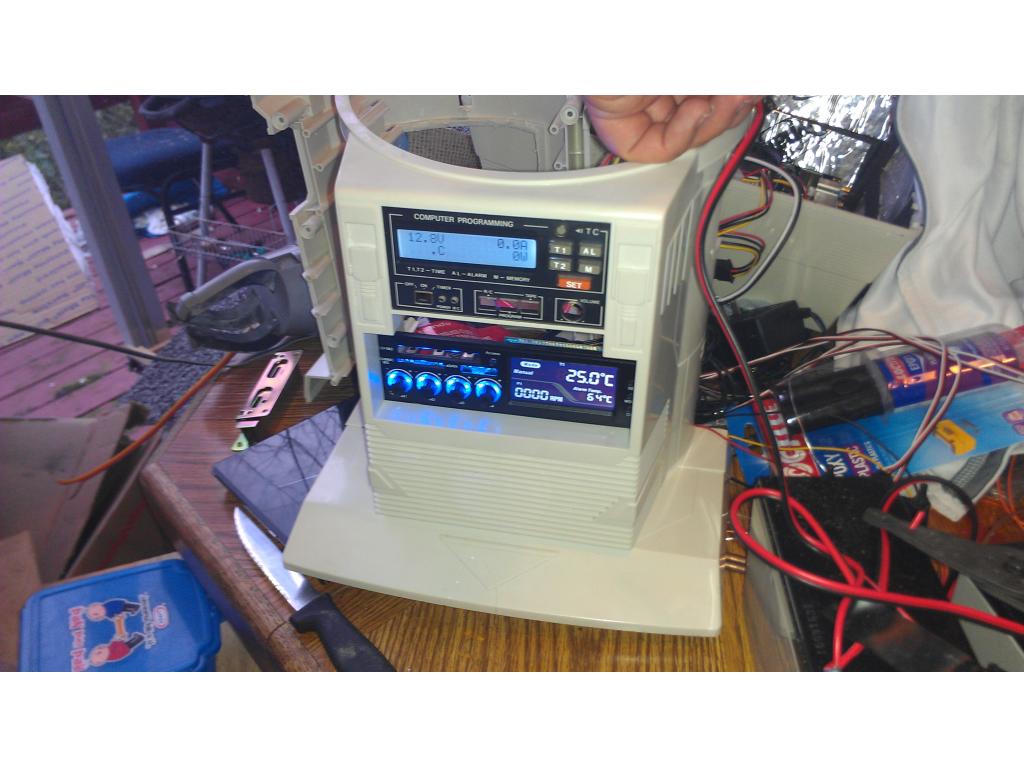
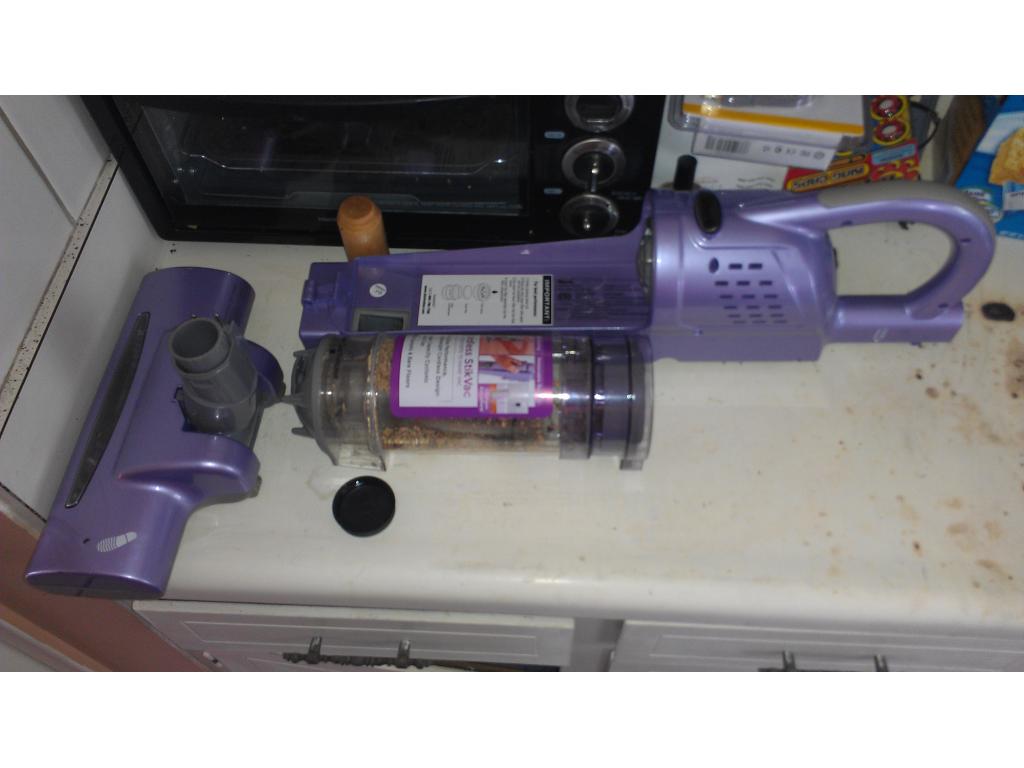
This project has evolved some , the basic rundown is I'm modding two Omnibots , one a regular the other a larger 2000 model. I will have two ezb kits , rad base idea was thrown out because of so much noise but could go back on the table if the omnibot drivetrain is too weak to pull it.

By jstarne1
— Last update

Discover more robots
Toymaker's My Little Dewey (Drone 1) New Home
Inventor/roboticist studio features an Alexa-controlled Dewey Drone aboard the Space Freighter Valley Forge diorama from...
DJ's DJ’S Test Platform (K8)
Synthiam ARC test robot: Devastator tank with Rock Pi/X, Sabertooth+Kangaroo, Realsense D435i/T265 for autonomous...
DJ's And Now For Something Completely Different (Pdp-8)
VC8E oscilloscope emulator for PiDP-8 using Synthiam ARC: phosphor fade, configurable refresh, pixel size, intensity,...

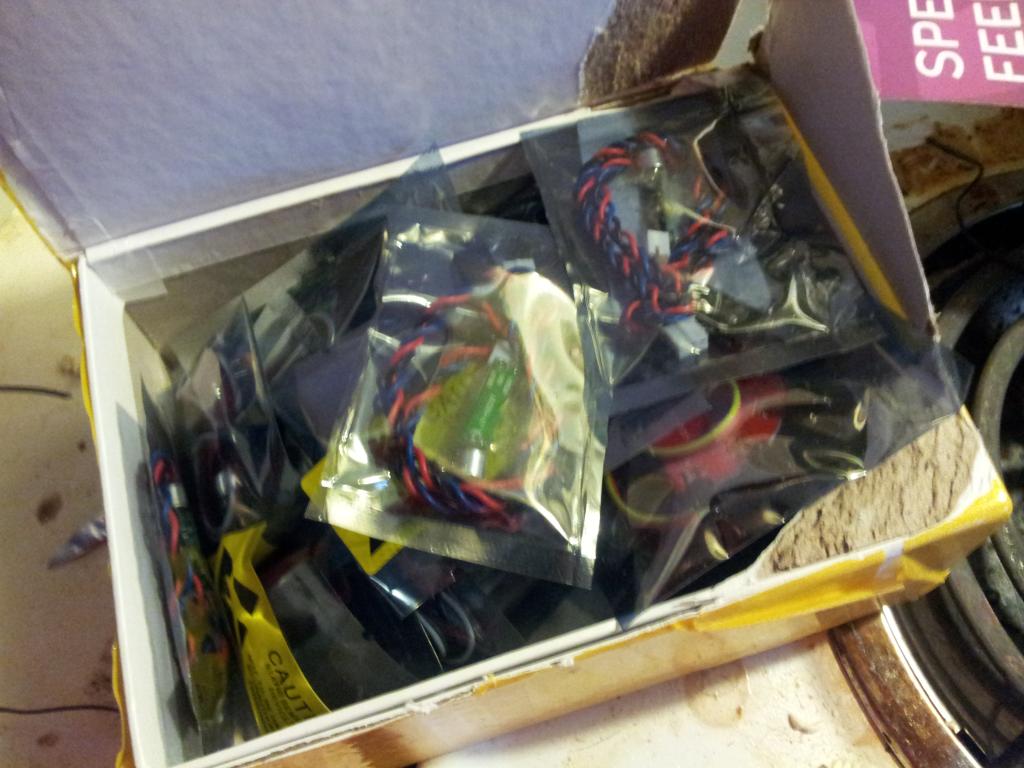
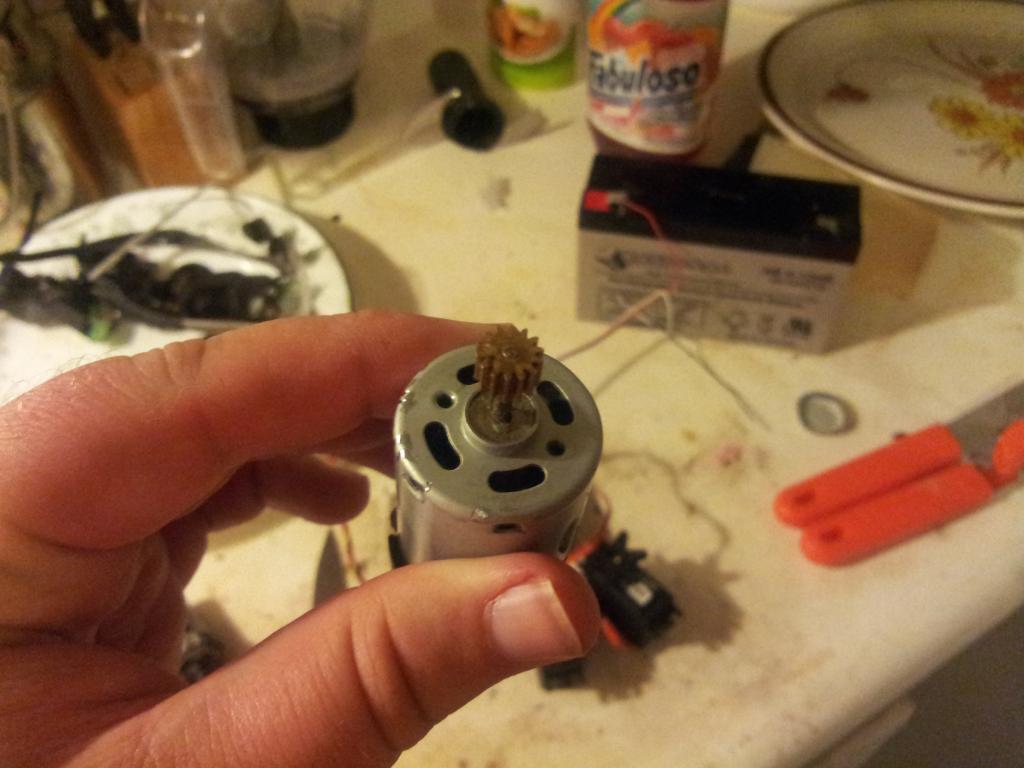
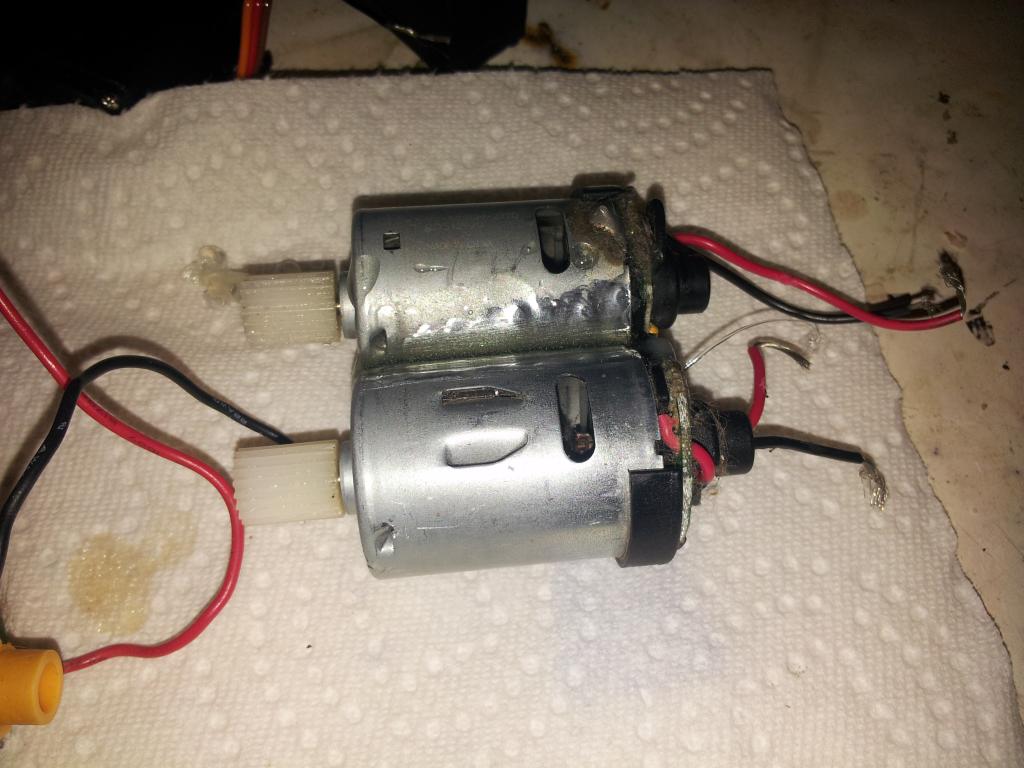
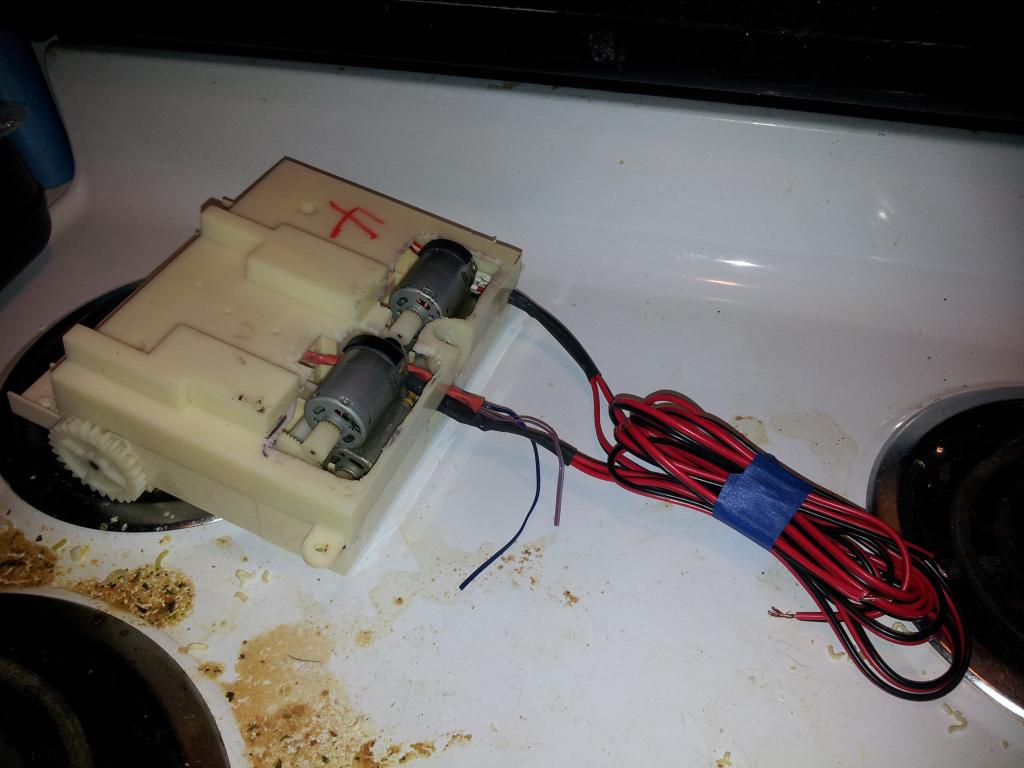
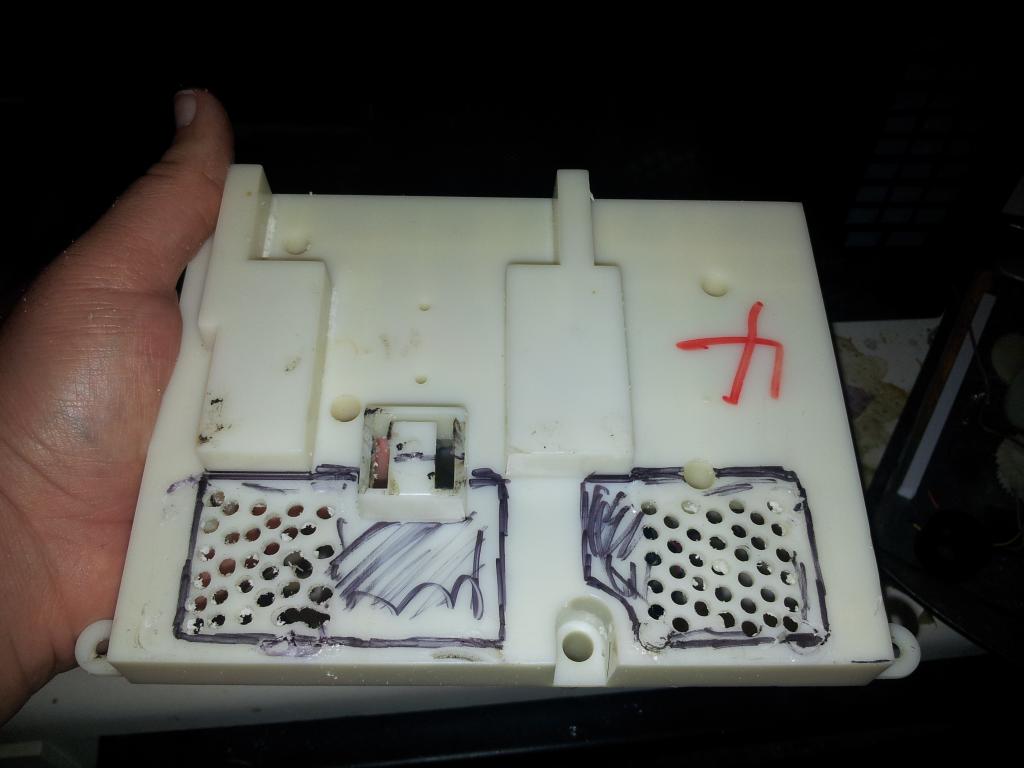
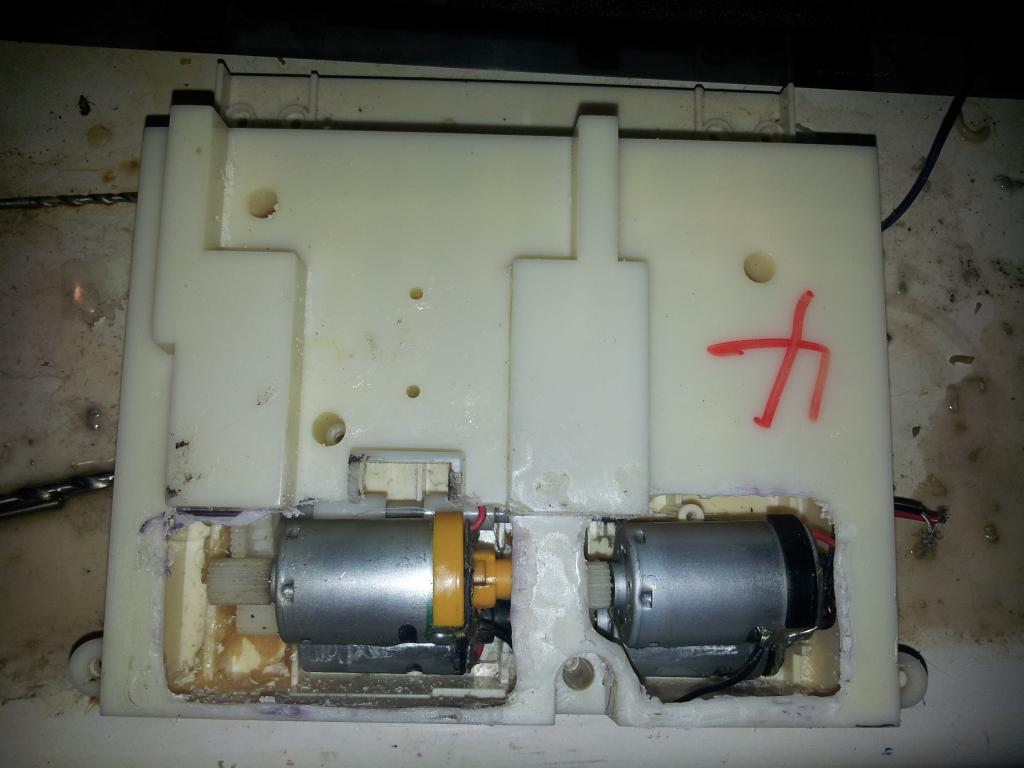
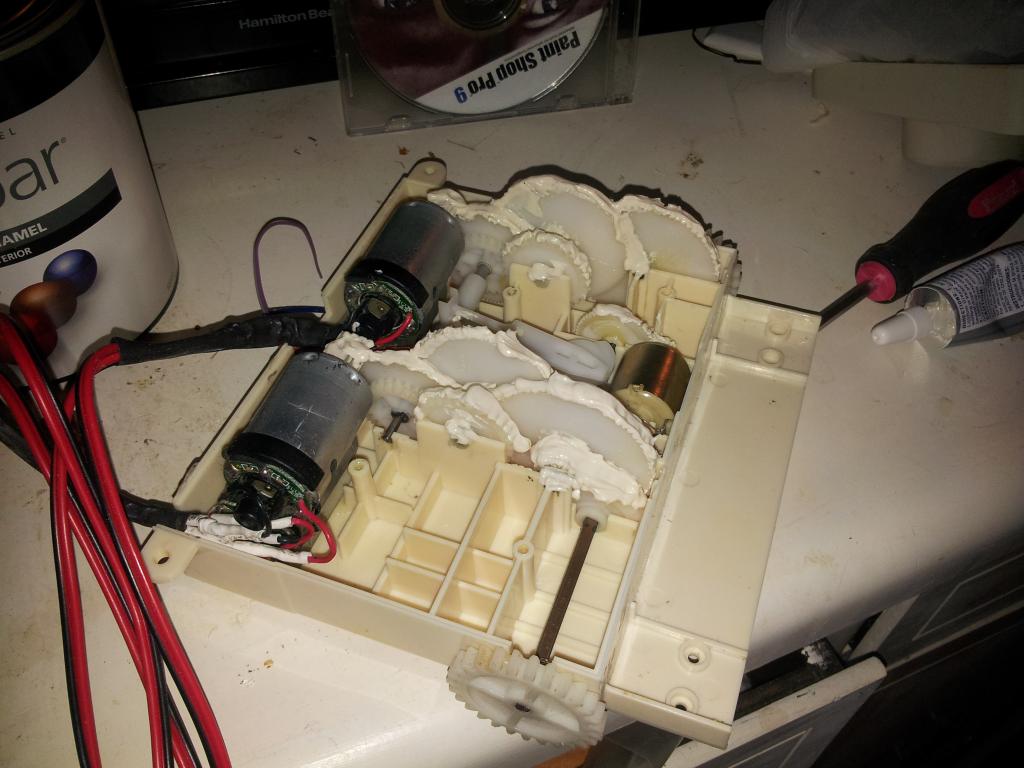
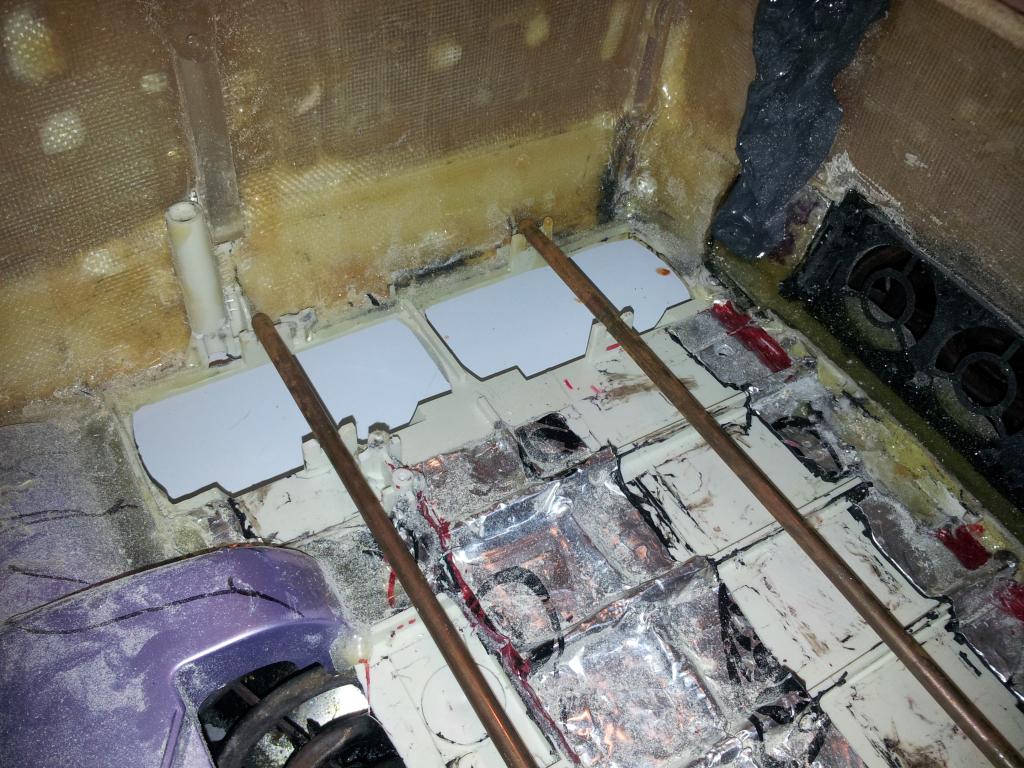
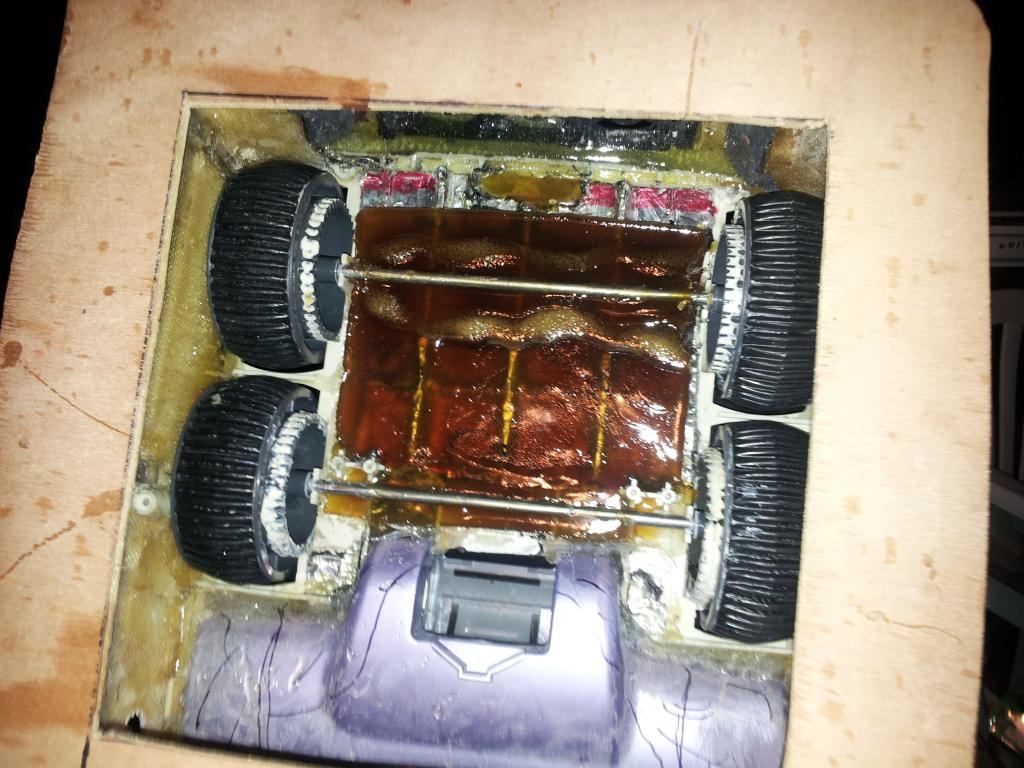
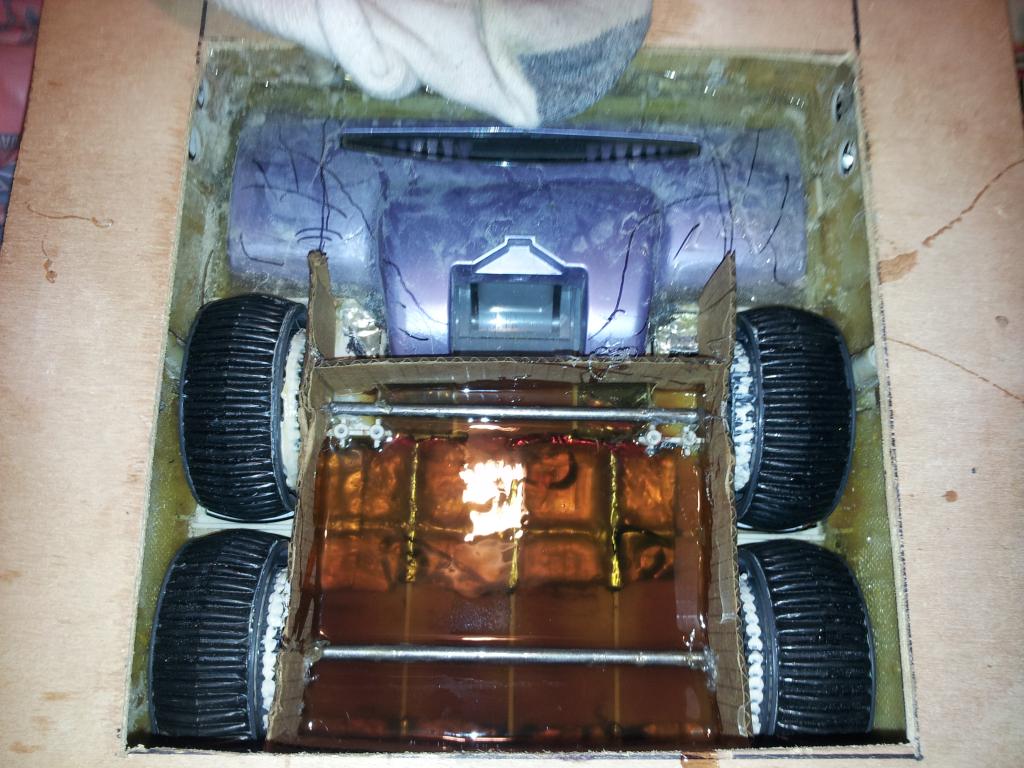
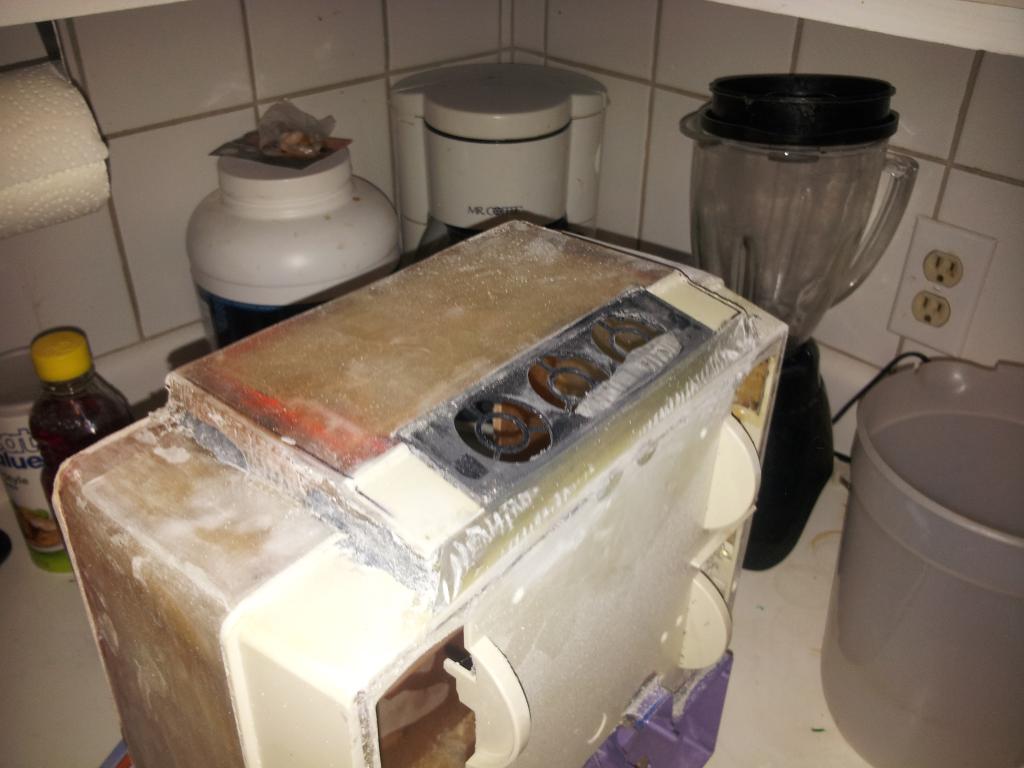
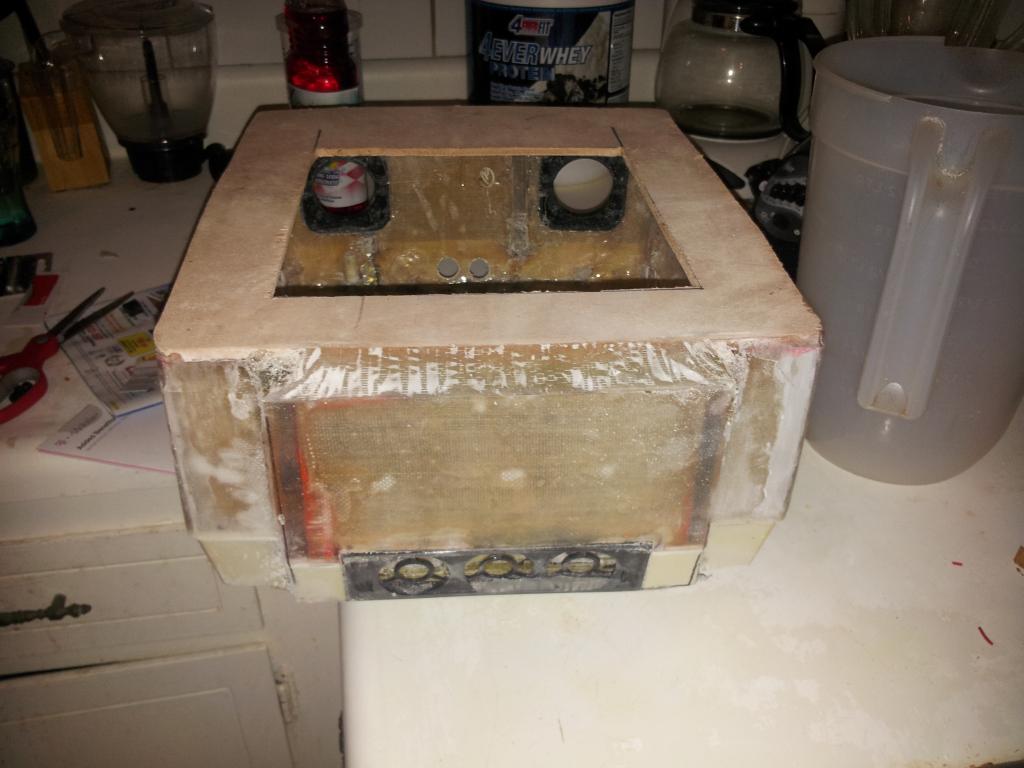
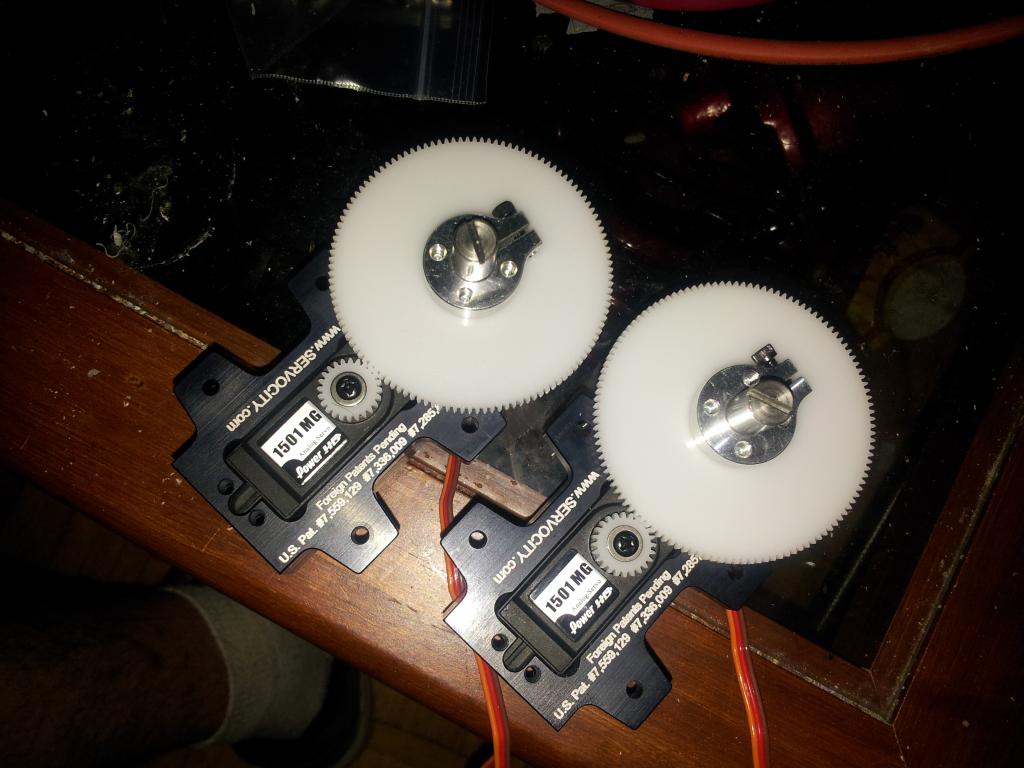
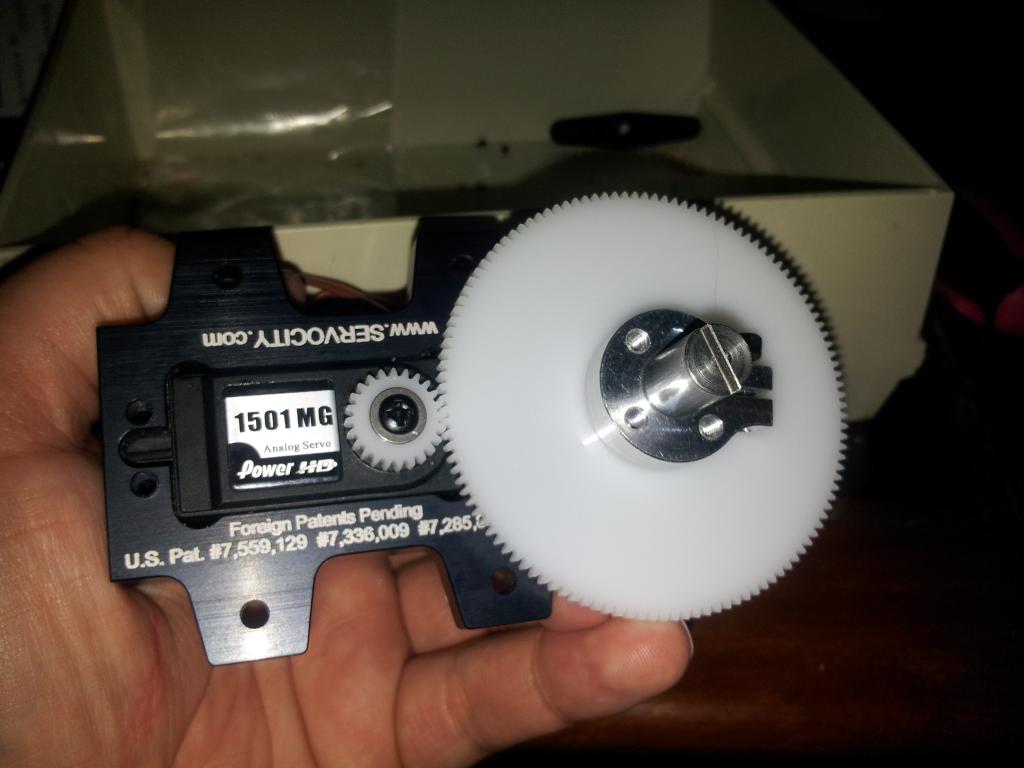
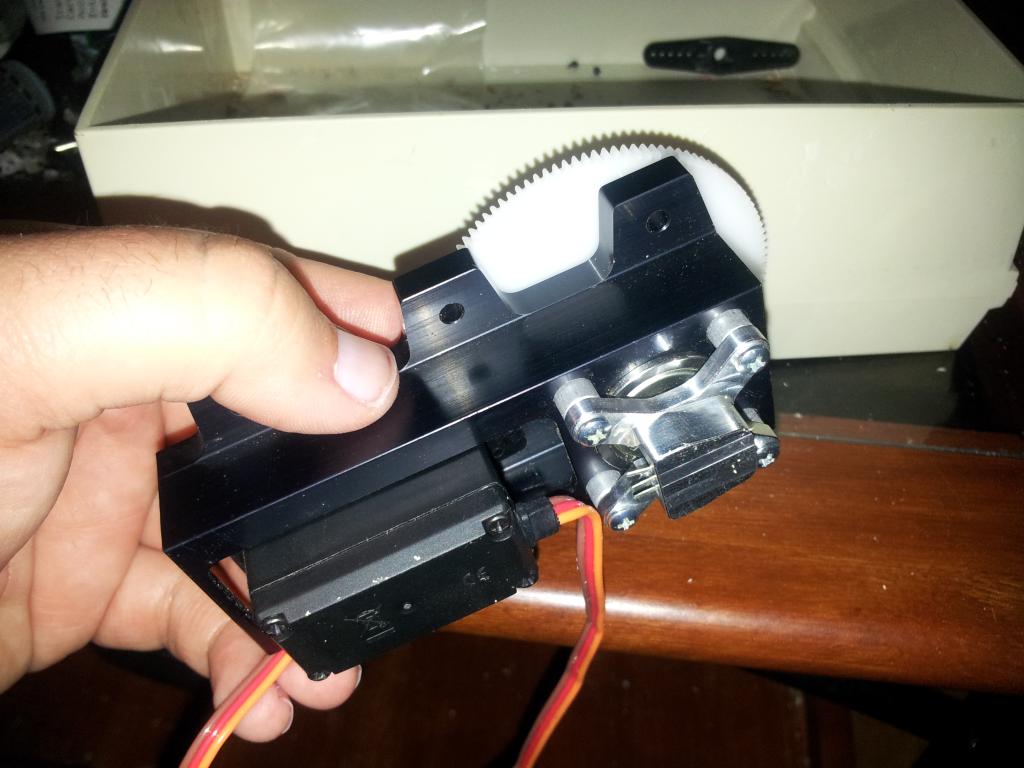
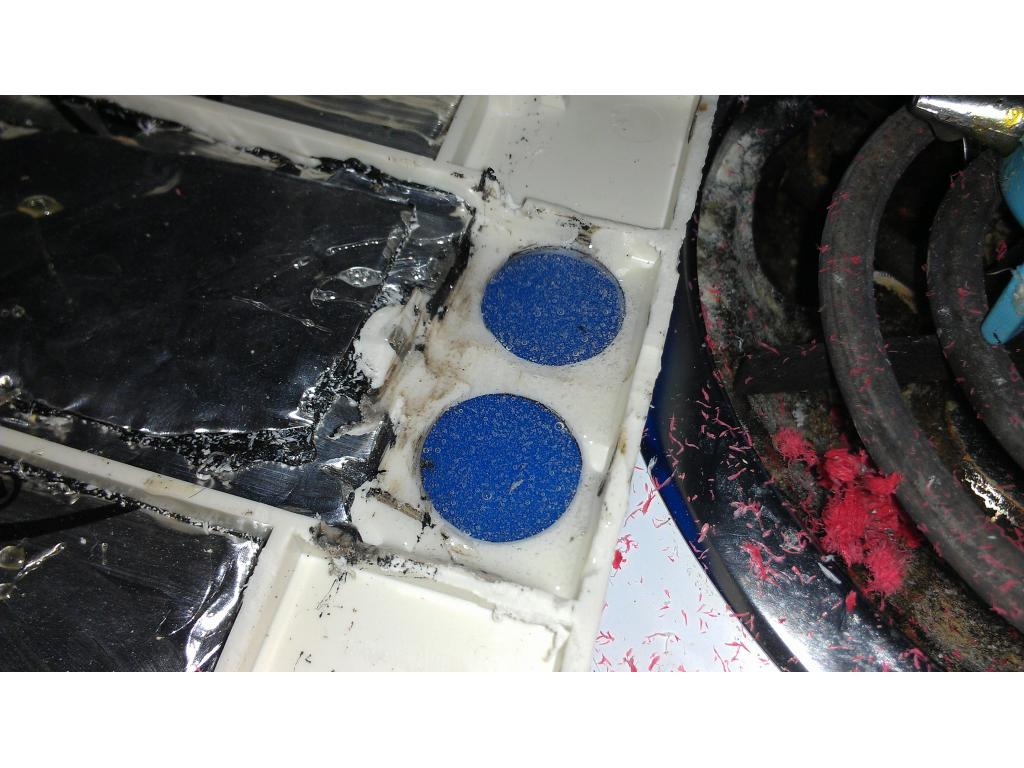
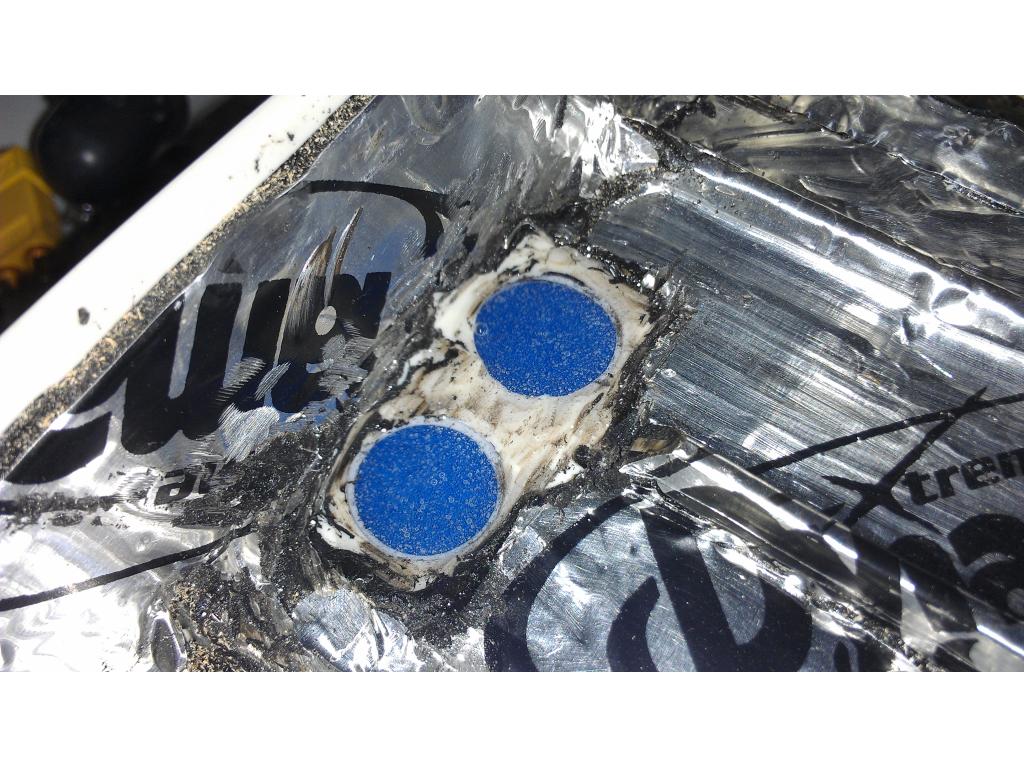
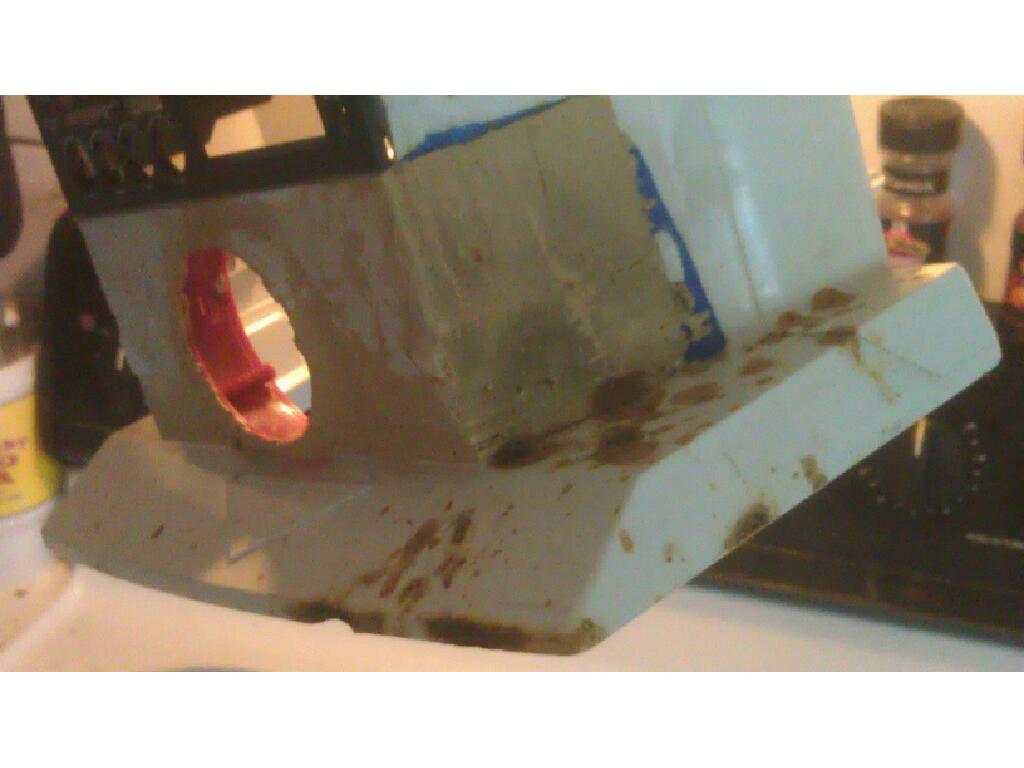
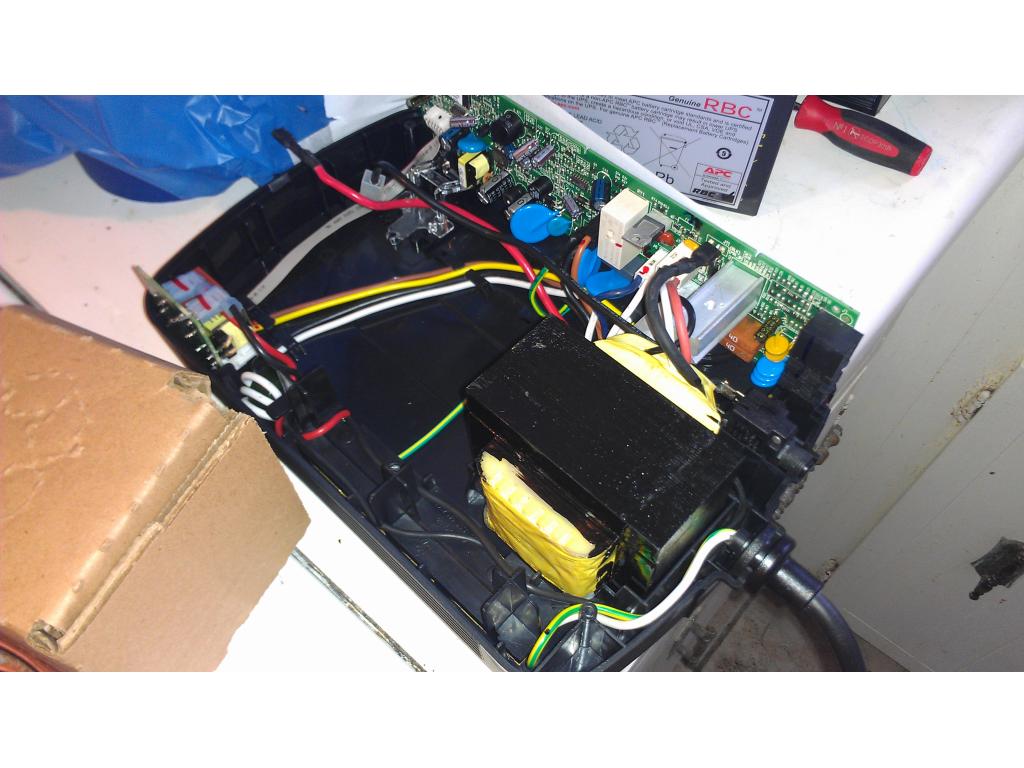
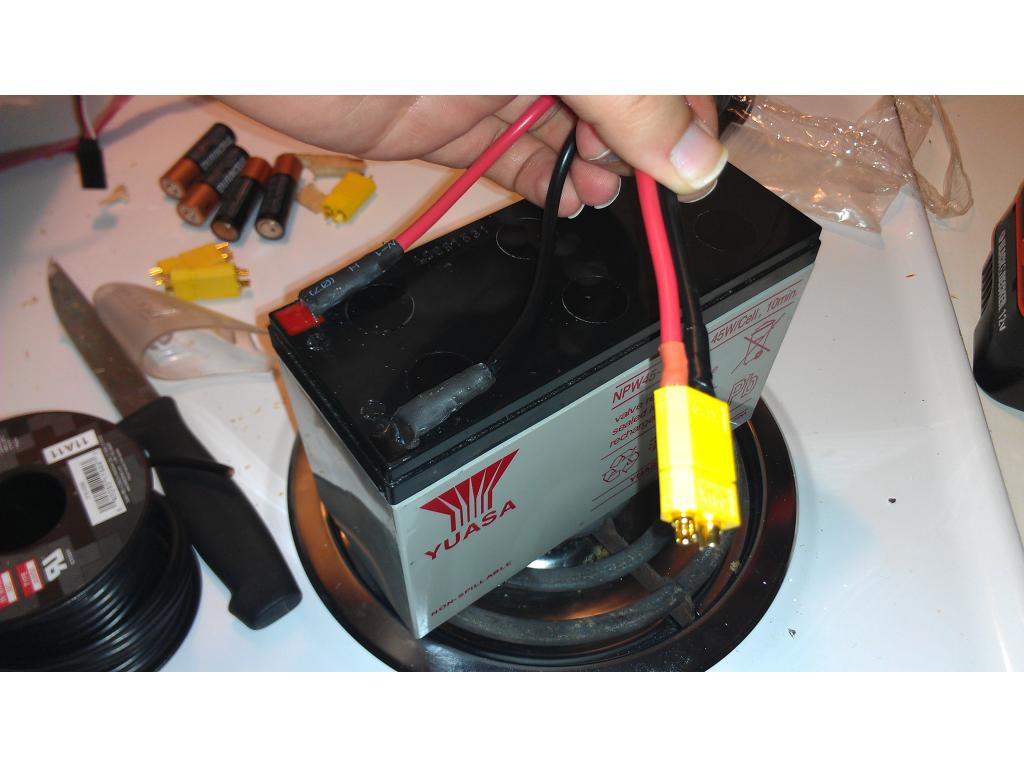
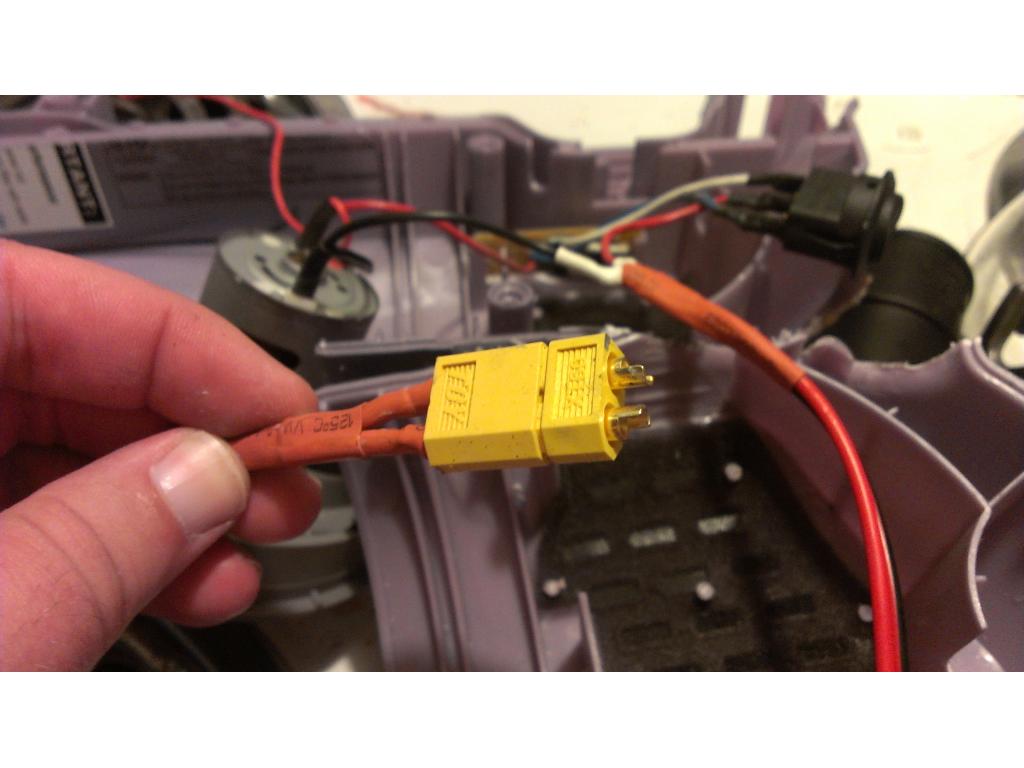
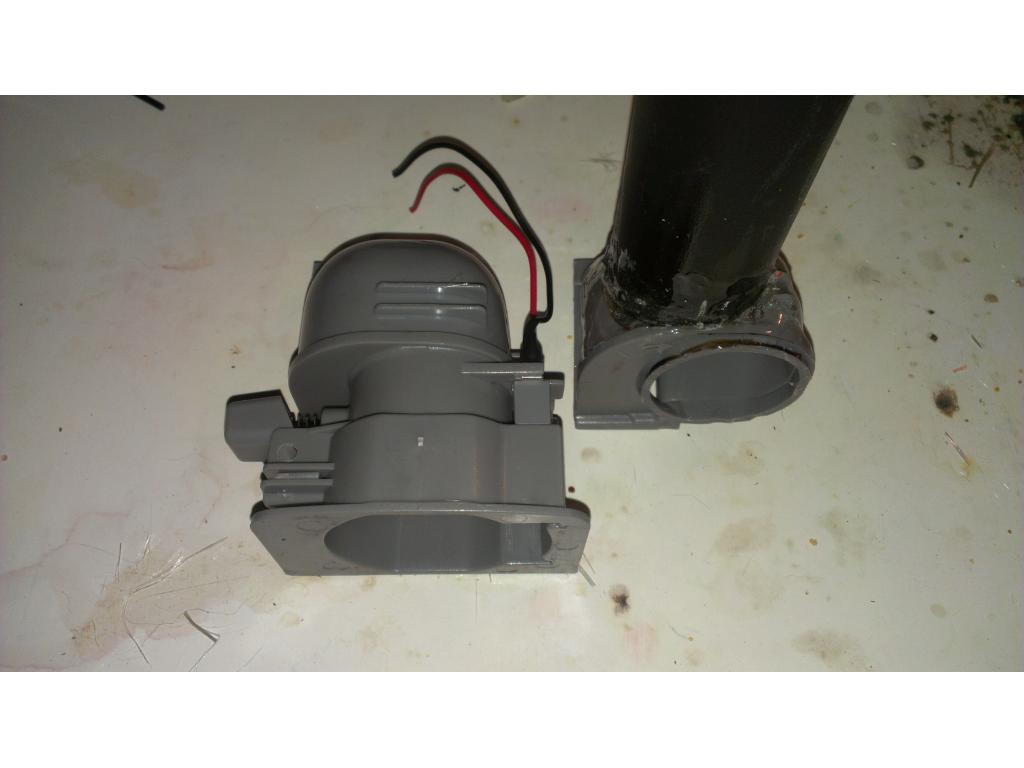
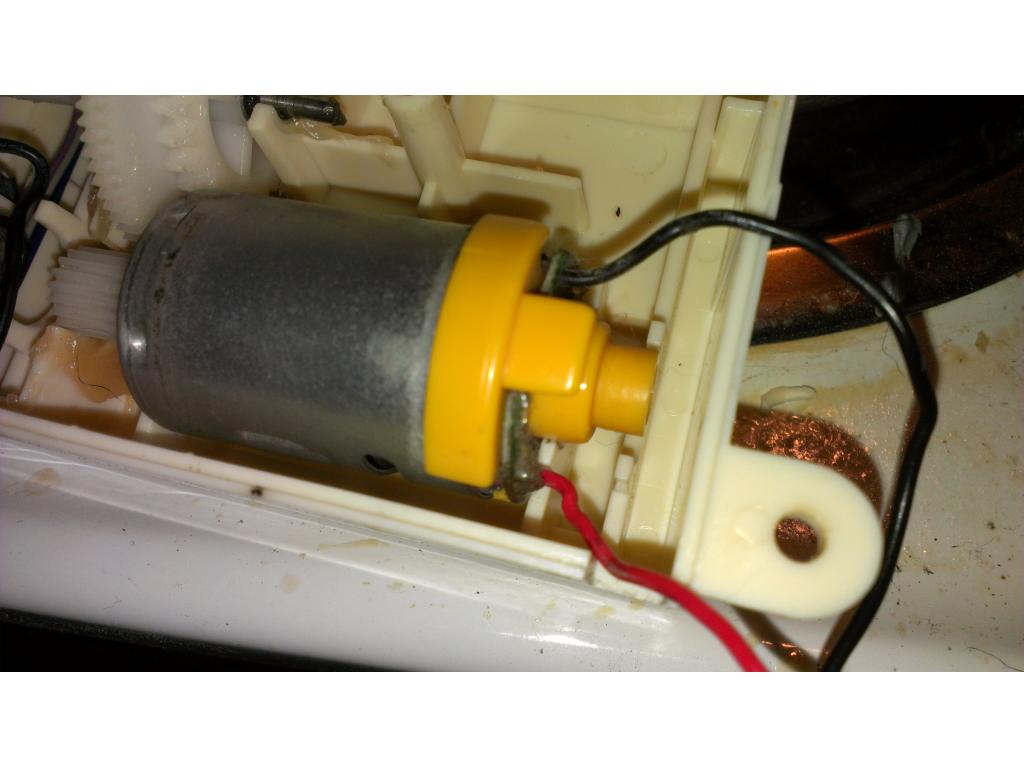
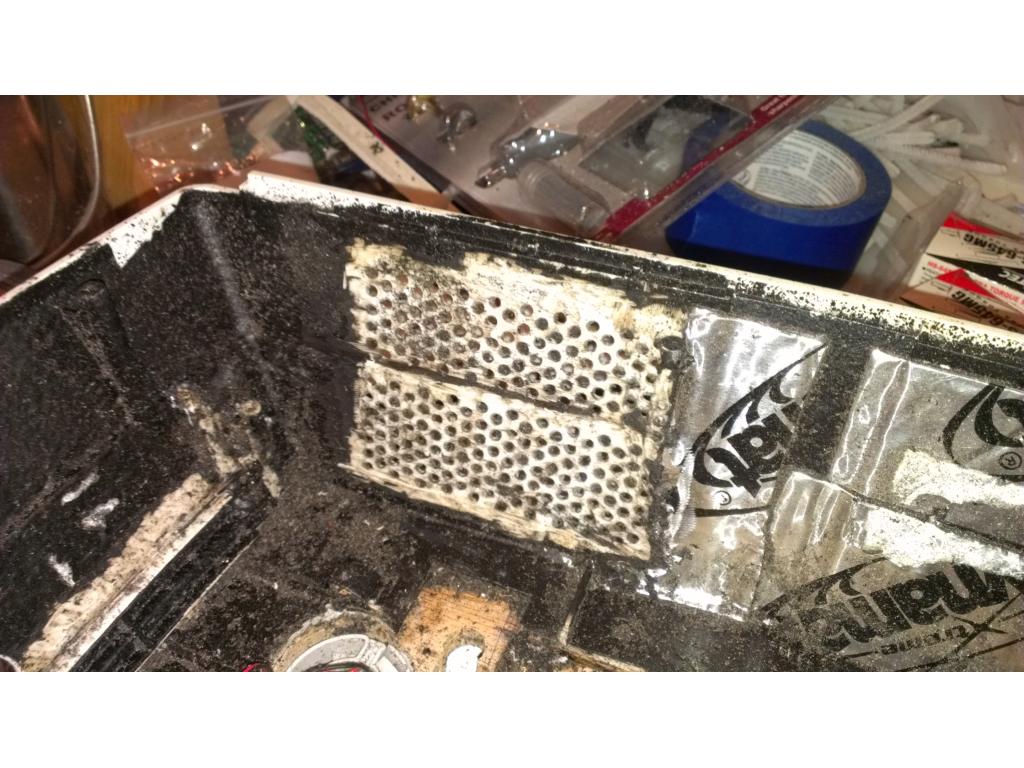
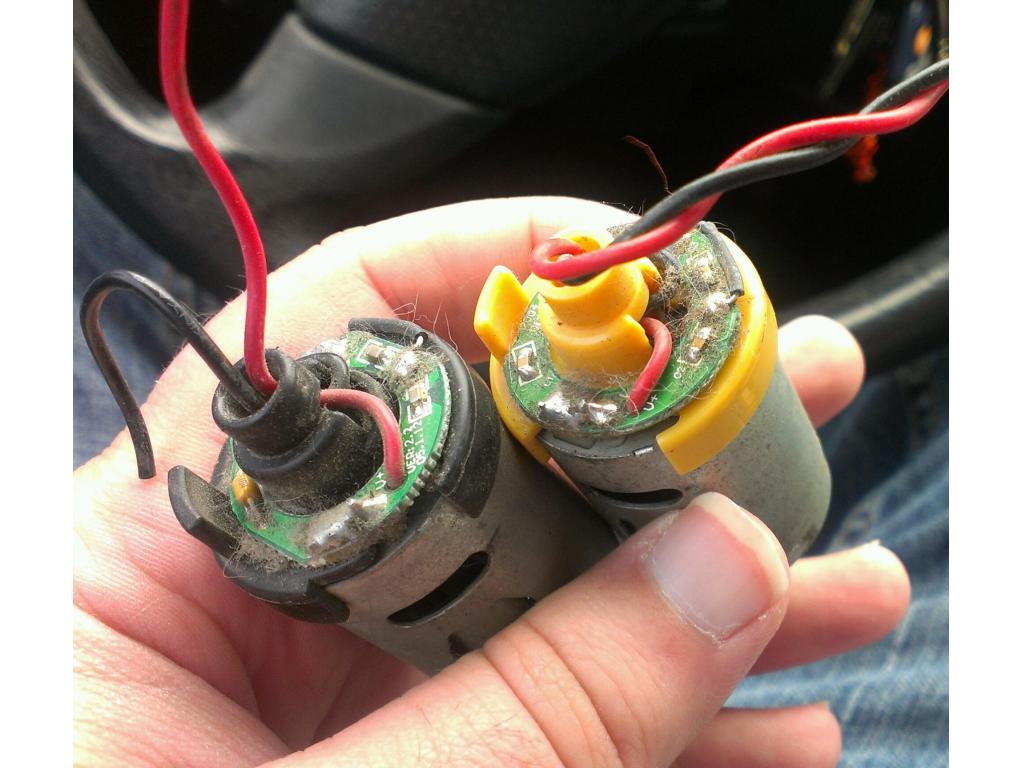
I soldered on power leads and covered the connections with heat shrink. Now I will probably just make a cover for the top to contain some noise and then I will cover it with a couple layers of dynamat.
SO FAR IT LOOKS GOOD AND CORRECT
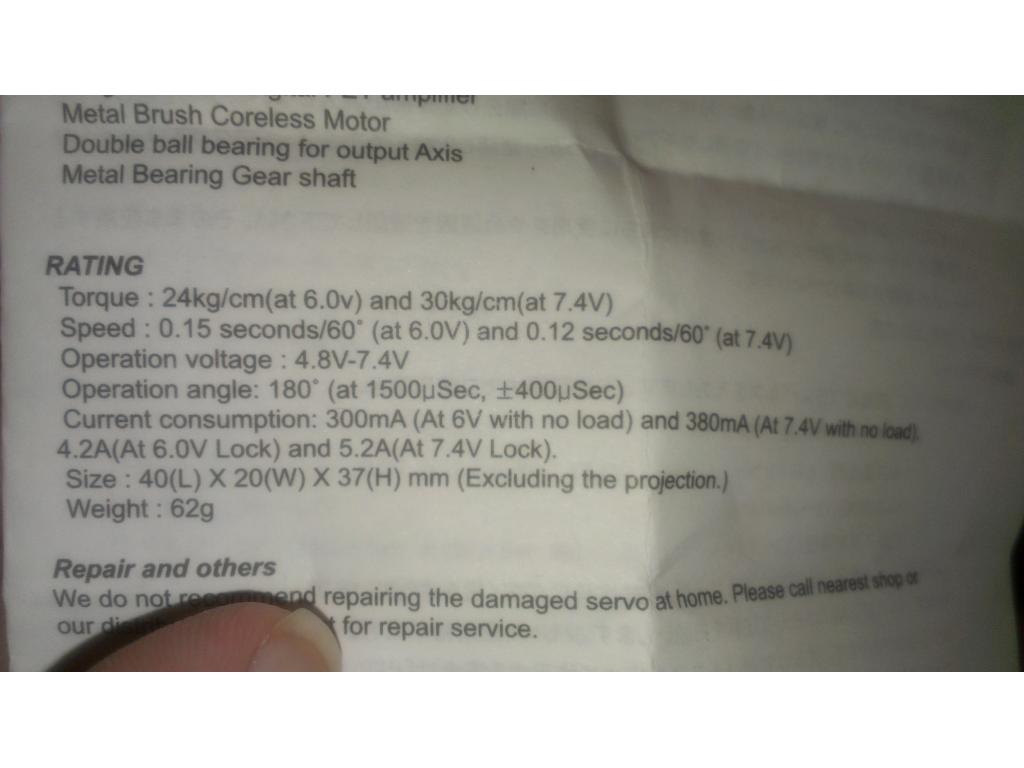
should handle 100 lbs or more,stall current will be very high so make shore your H-BRIDGE handles it
Thanks , I have l298 and a 10a hbridge .
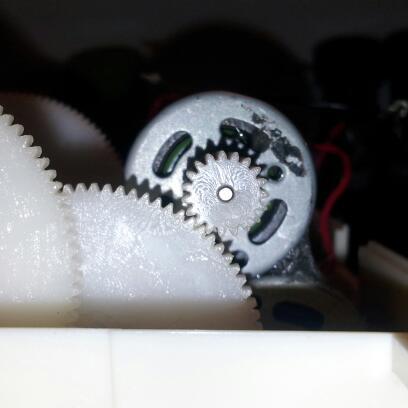
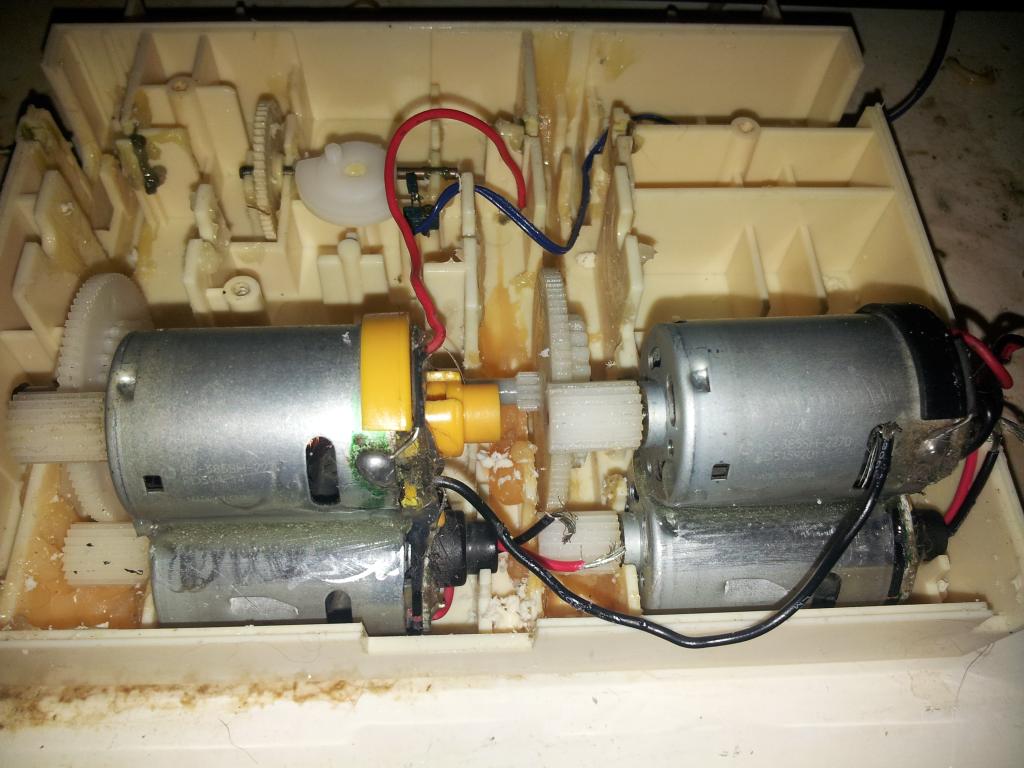
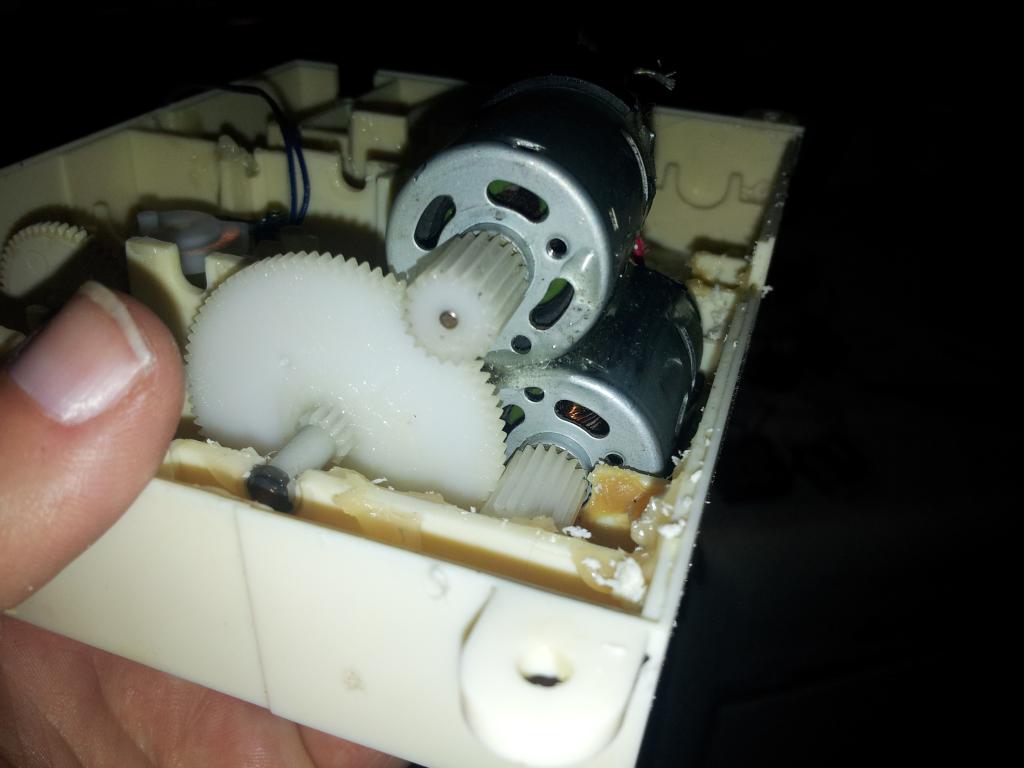
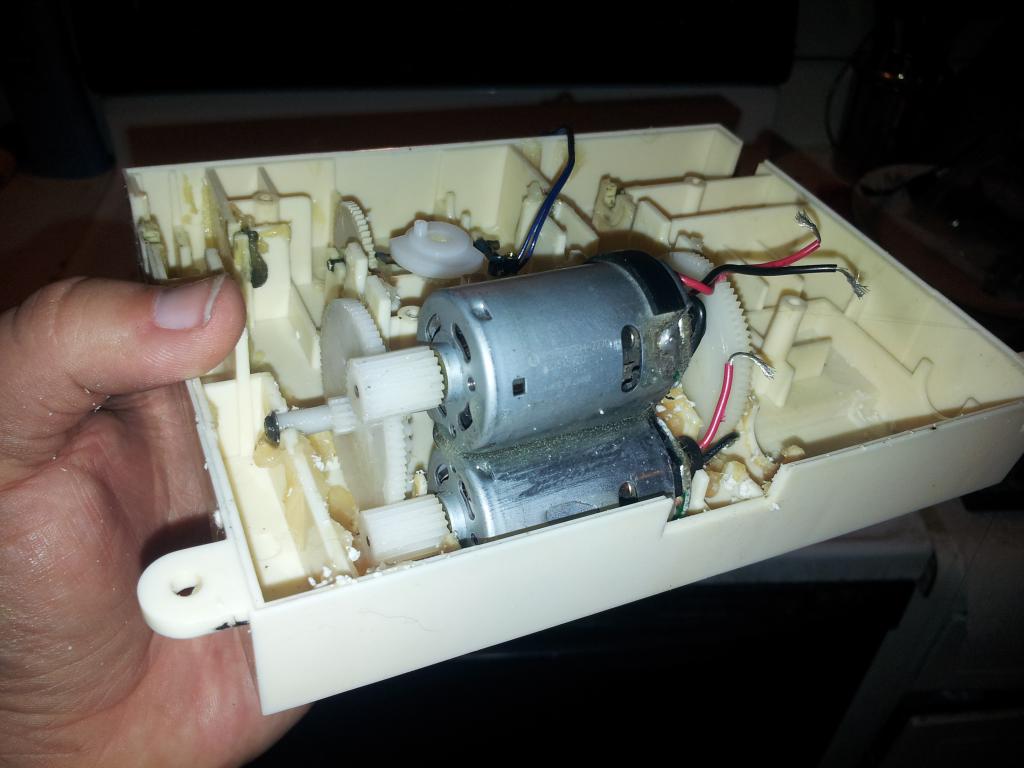
Nice work Josh! THat should move it around with ease. I like the way you paired them up - simple and effective.
i think it needs 1O AMP bridge,since using only one motor per side on the roomba it takes 5 amp modification to the roomba circuit design i am working on and you are using 2 motors per side
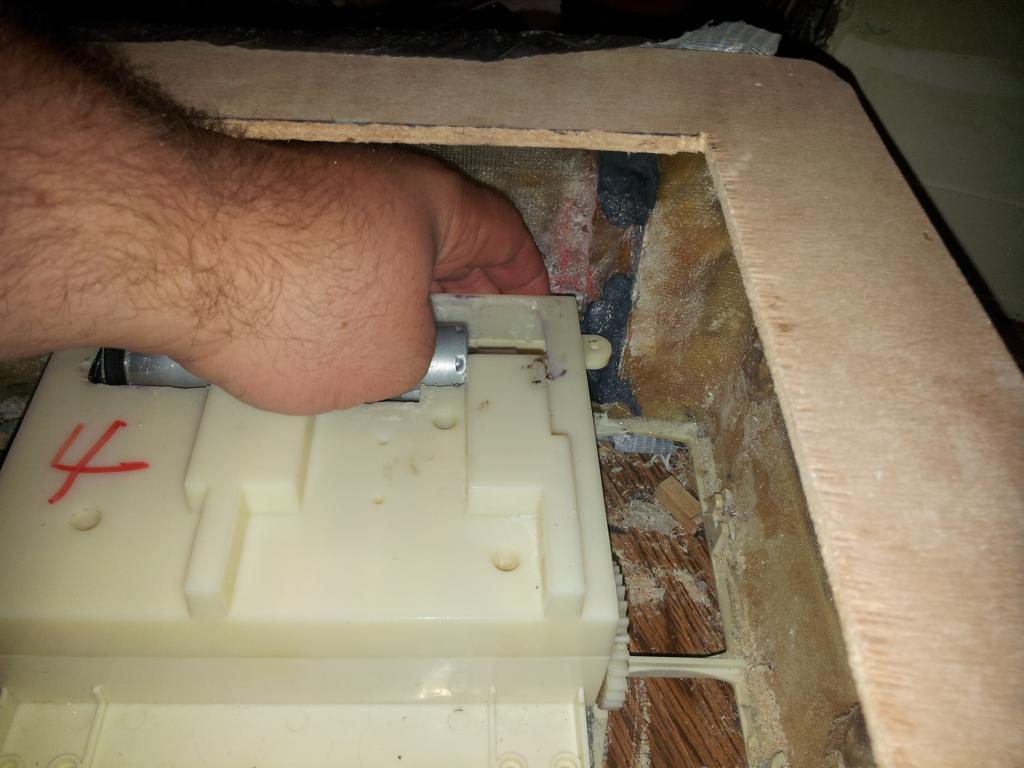
Looks like a perfect fit.
Nailed it!
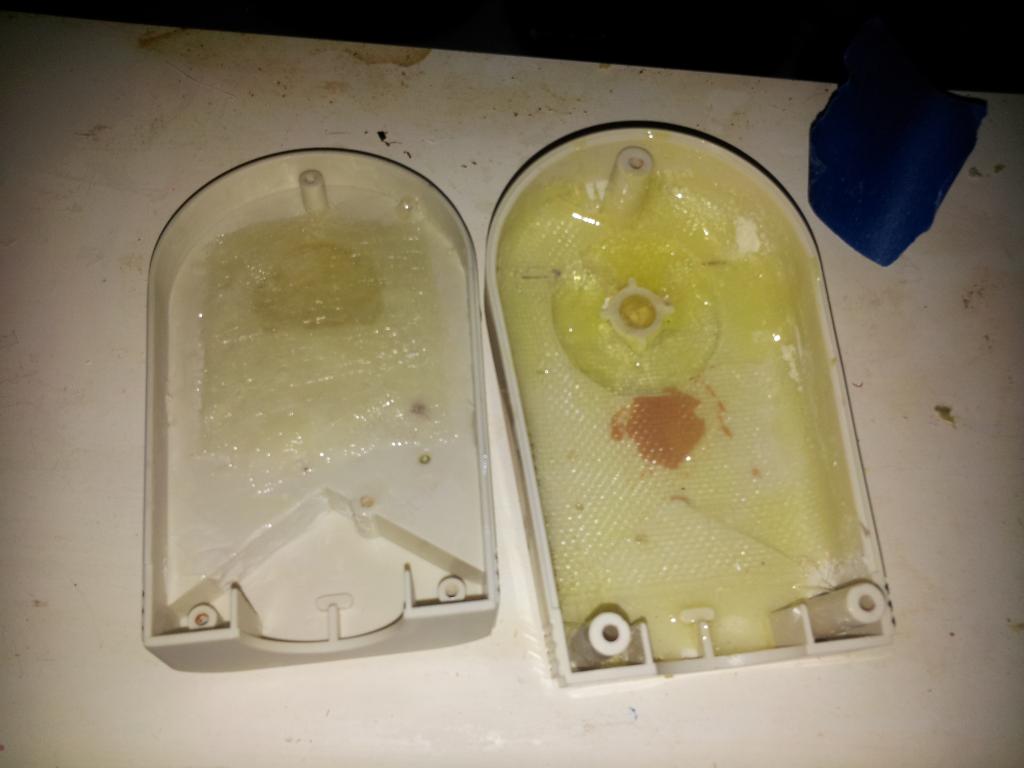
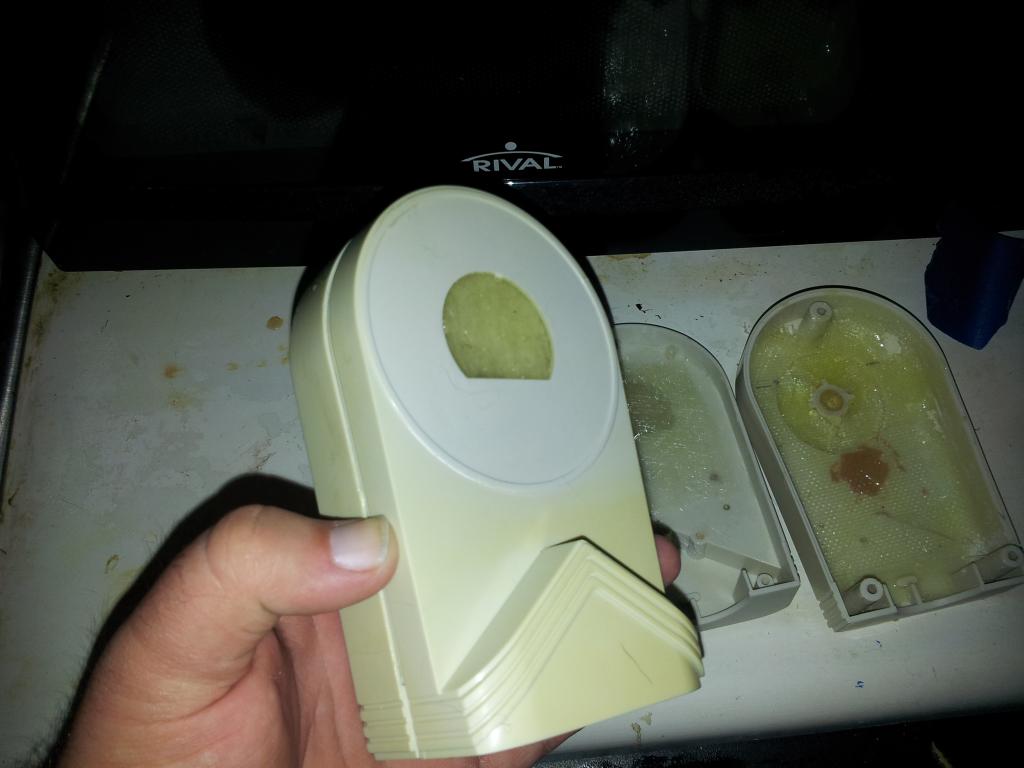
Thankyou everyone! This was a all nighters mod.
@Robotmaker I think that's the first time you straight up said I did a mod right! Lol
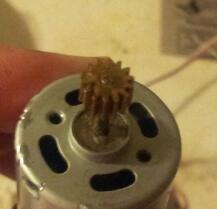
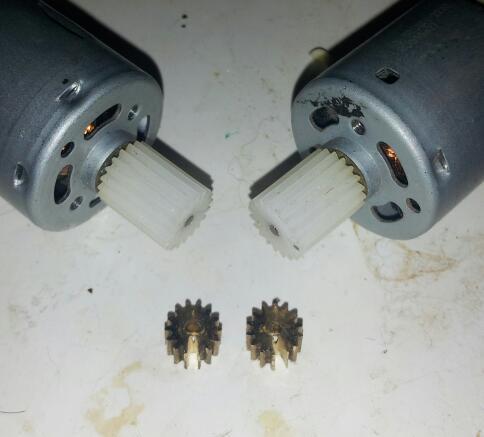
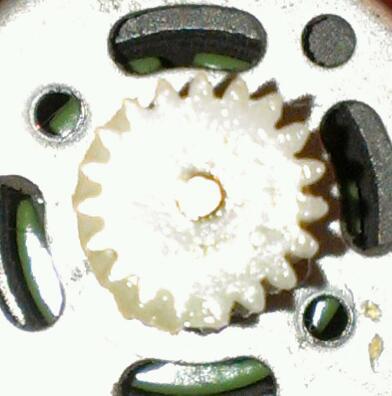
@Troy thanks for the set of pinions
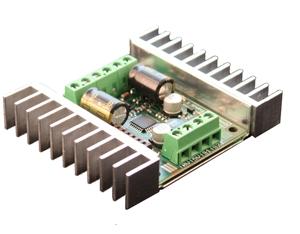
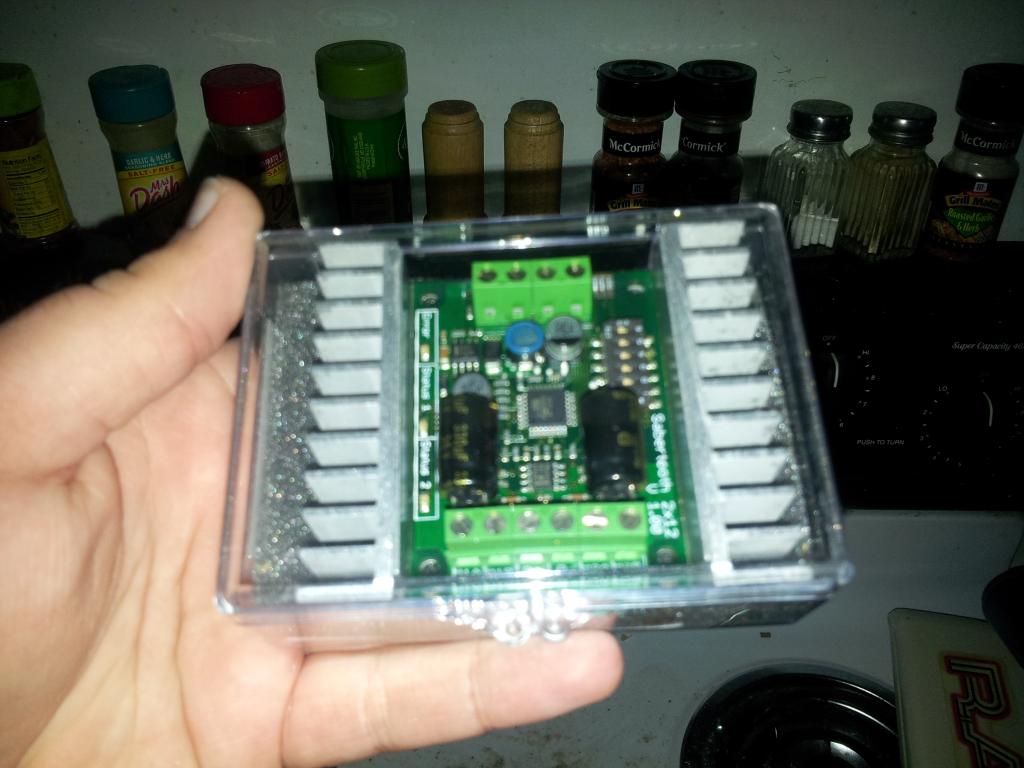
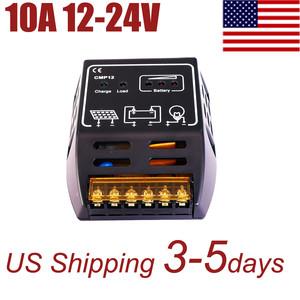
So I have that 10a controller but Brett had problems getting it to run. As always IM looking for simple yet effective. Should I just go buy a sabertooth controller and call it a day? Input please I want to order something today.