cE9s4PsOgeBQIORwjd5!~~60_1-634818020230156250.jpg)
Lupuc4g~~60_35-634706297915000000.jpg)
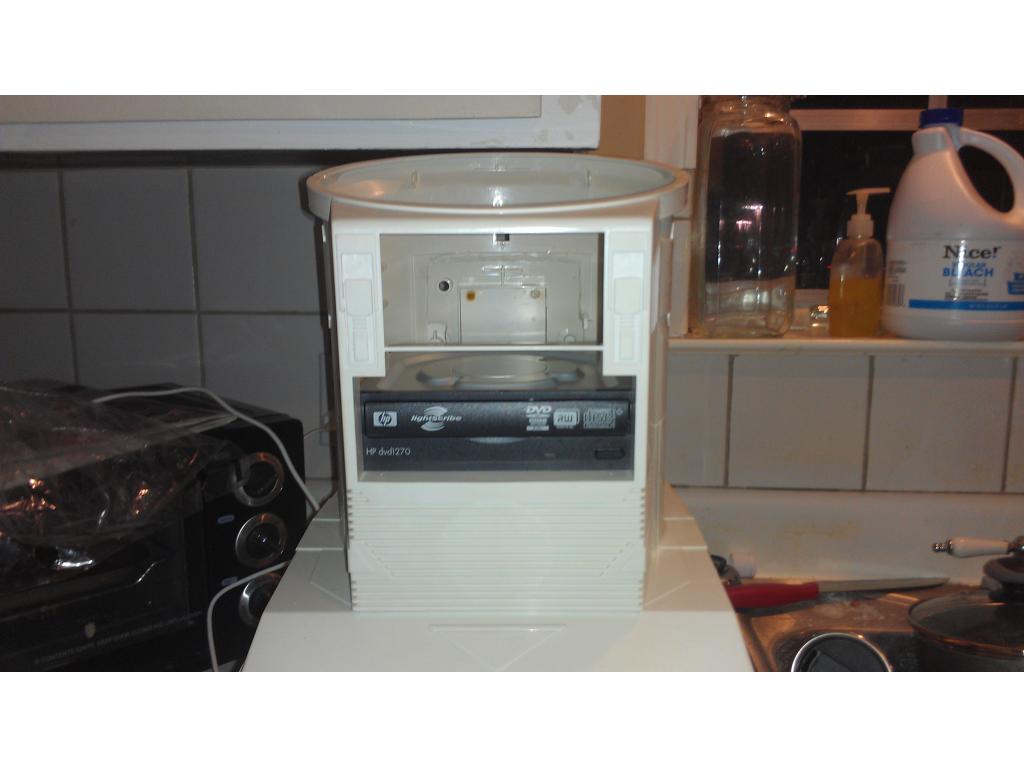
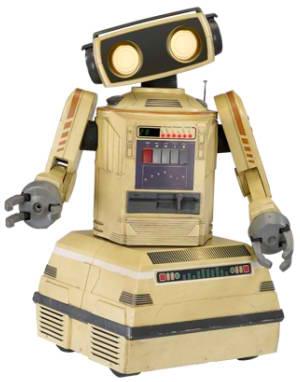
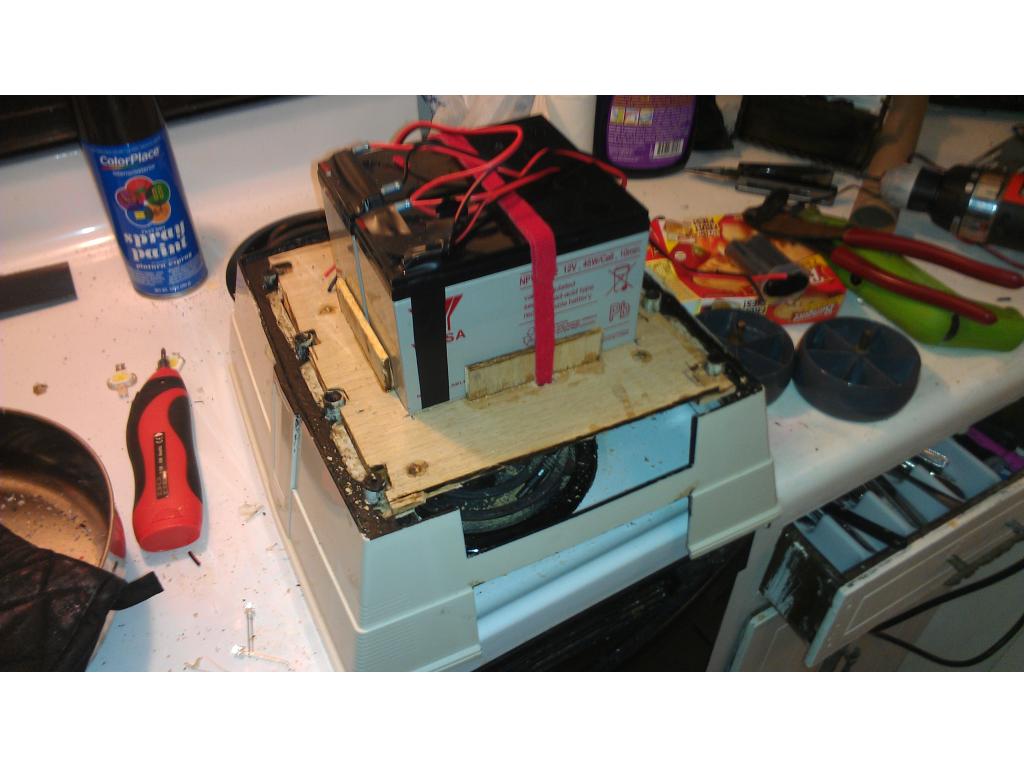
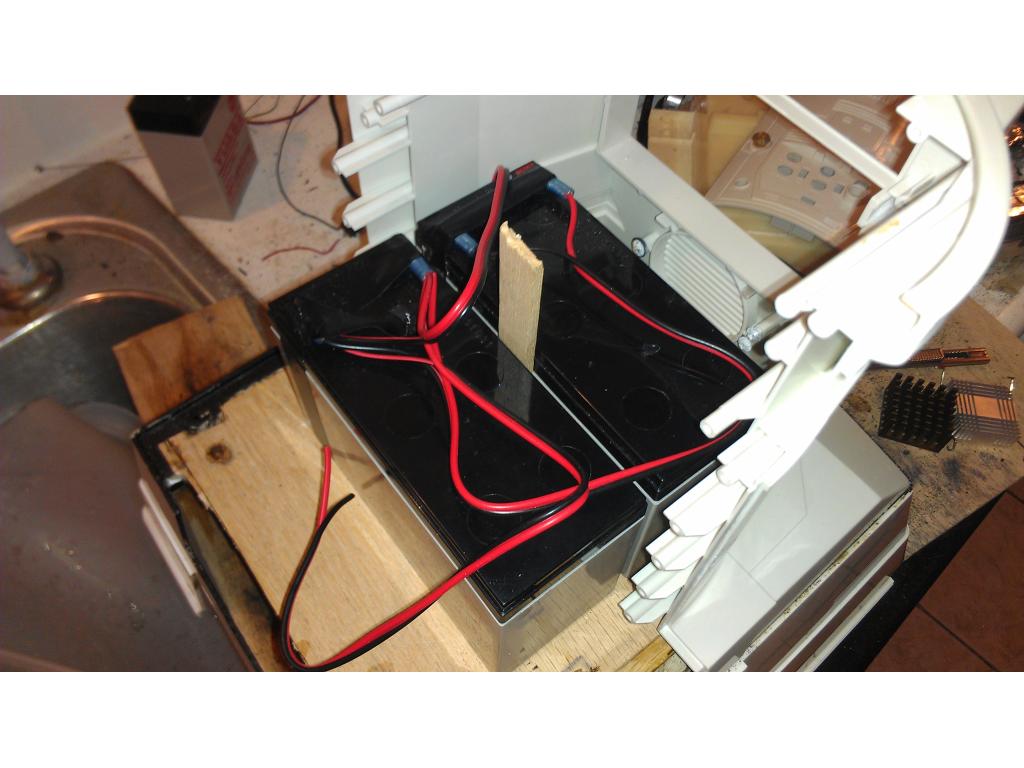
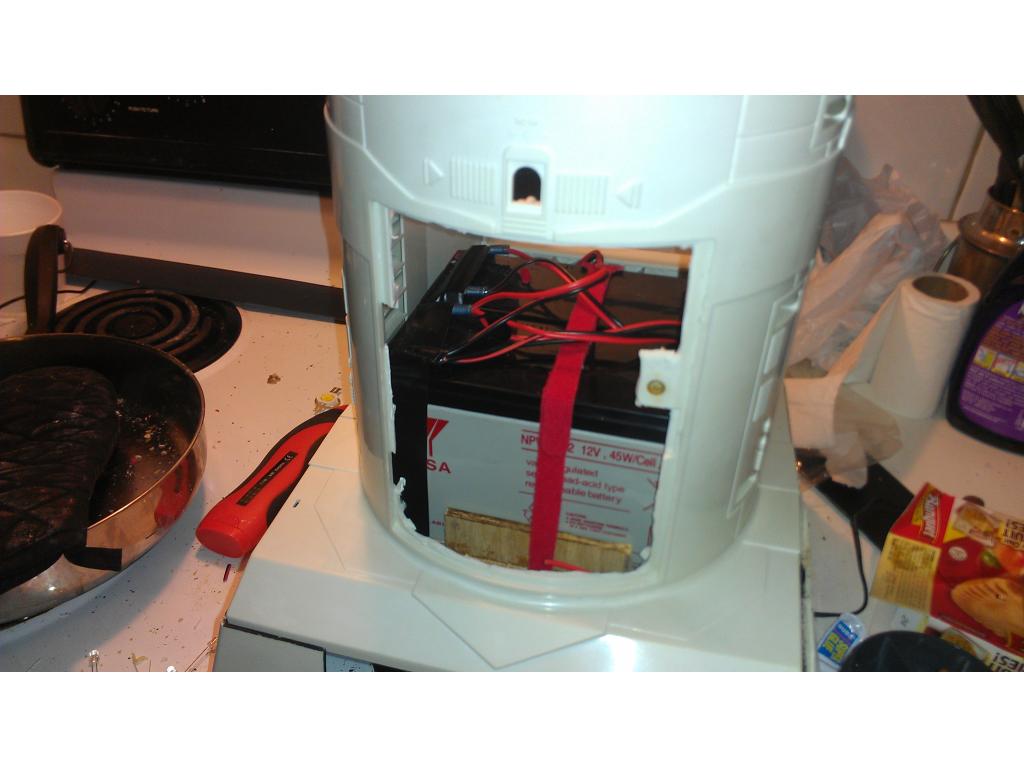
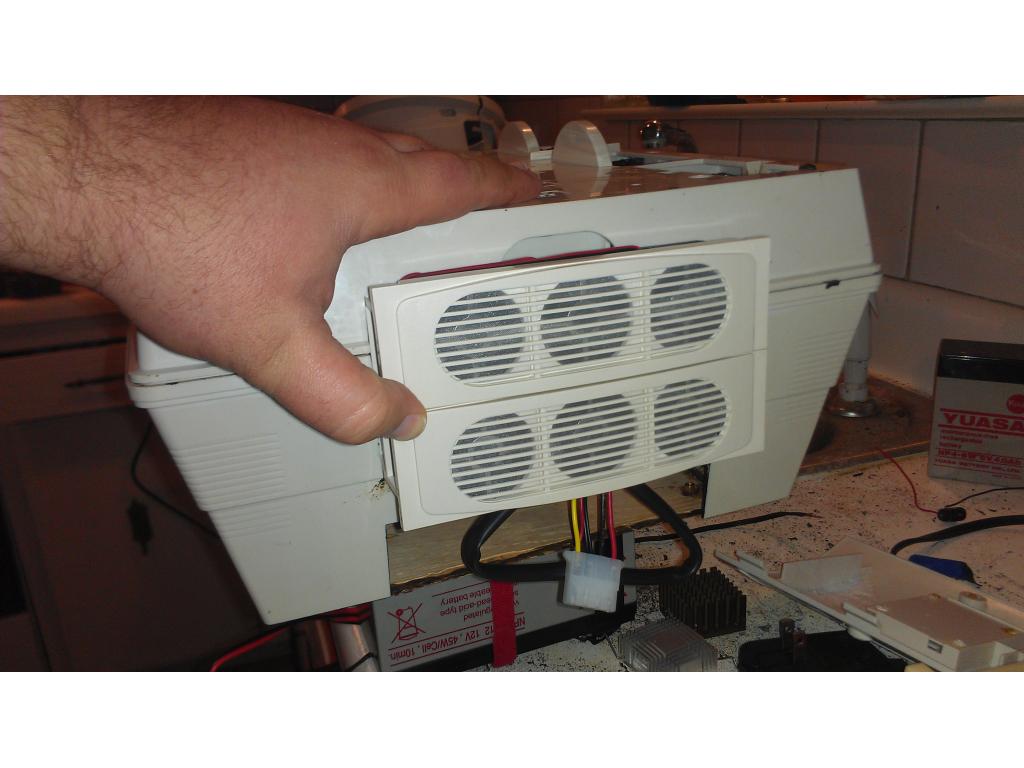
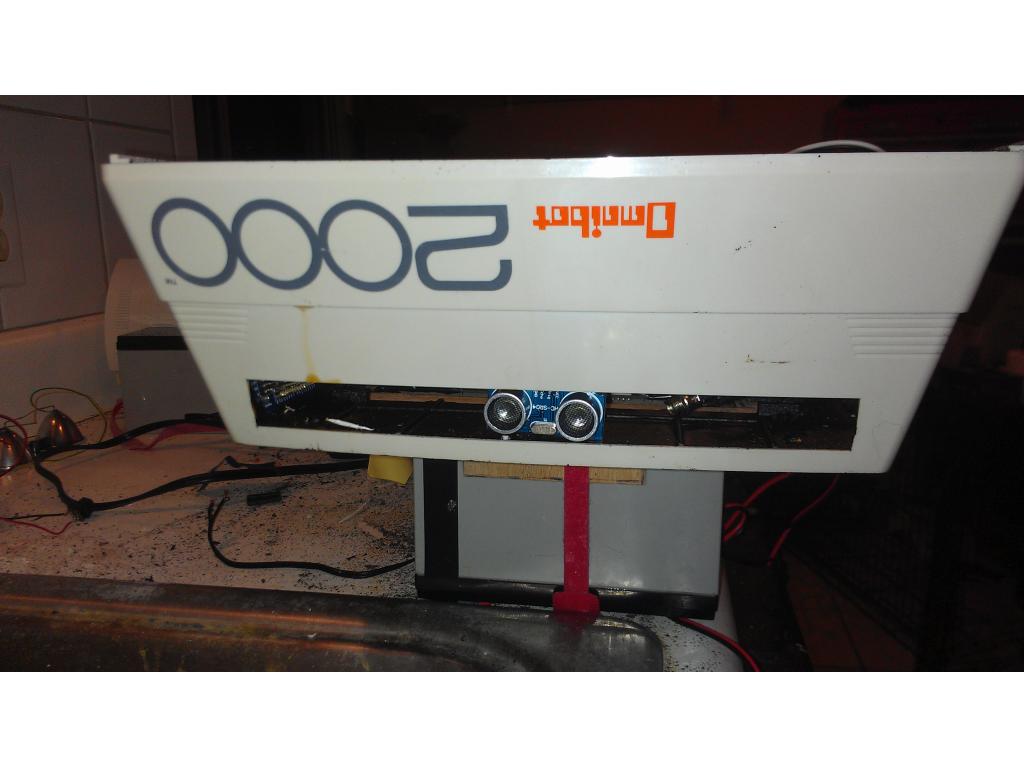
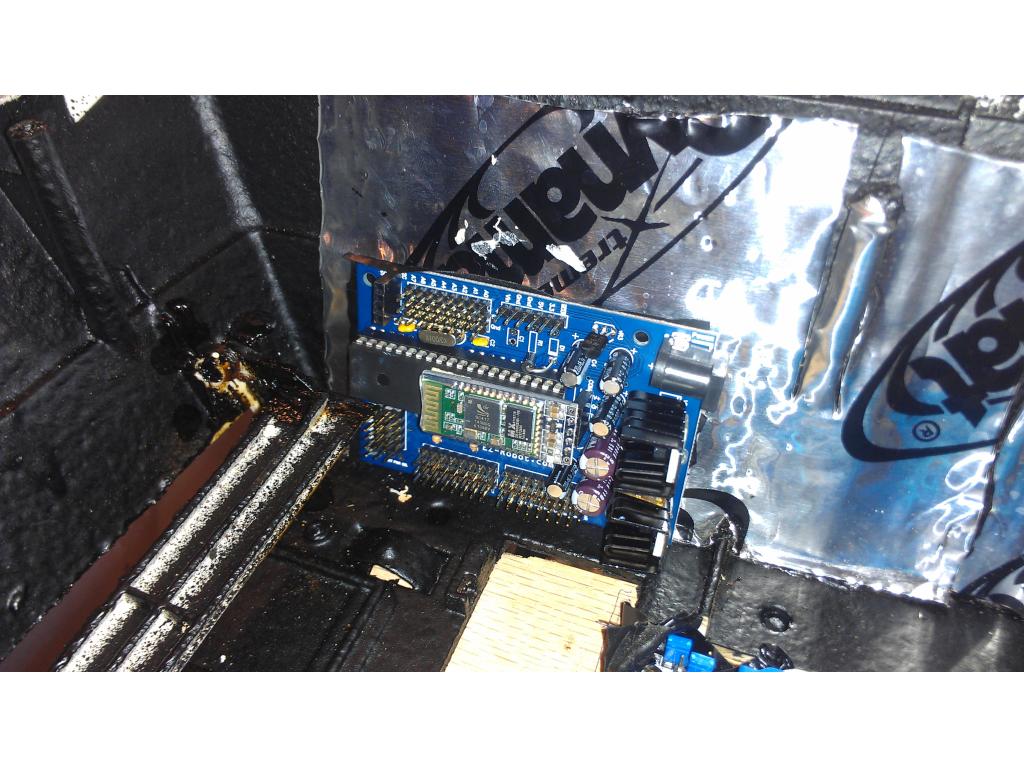
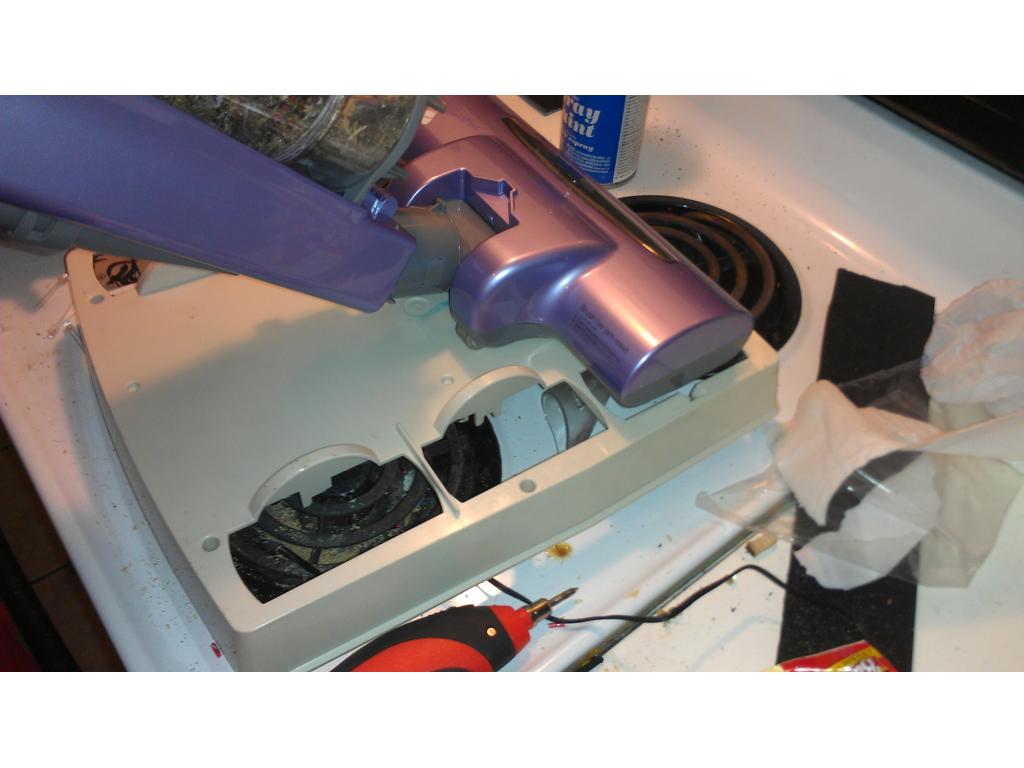
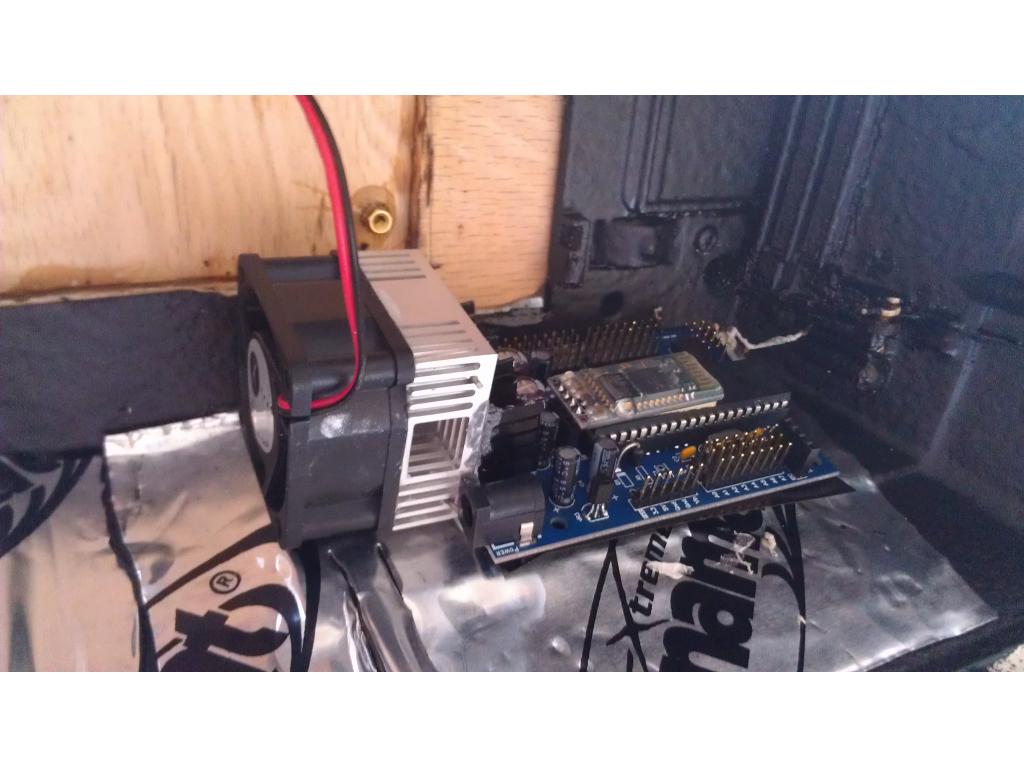
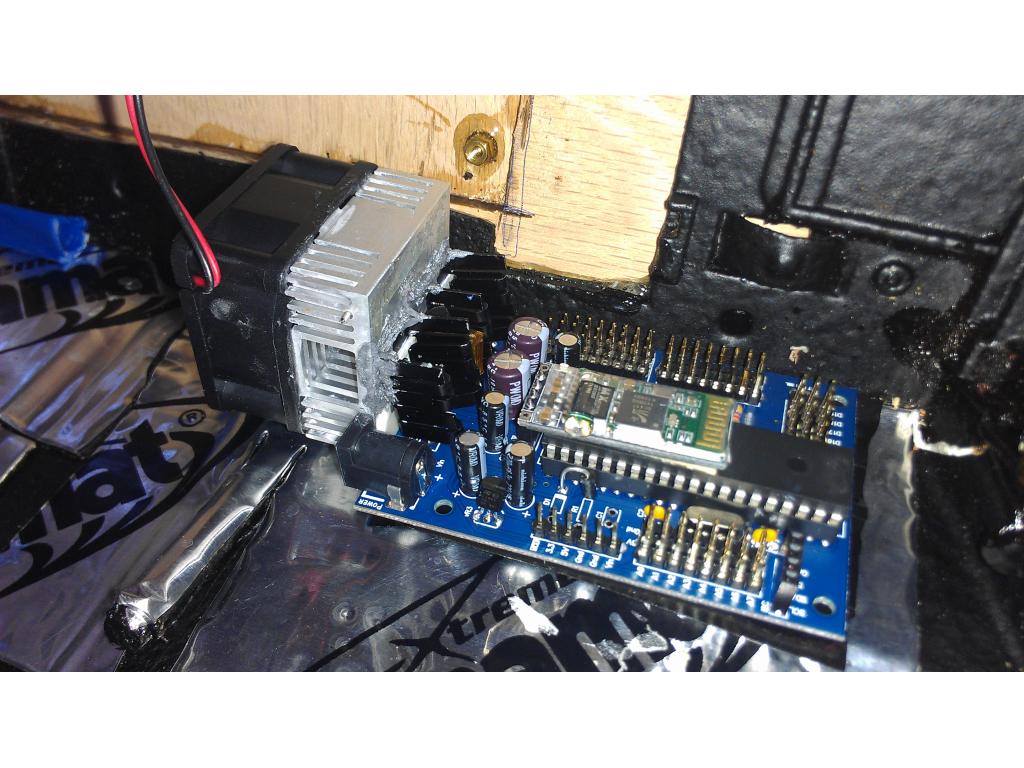
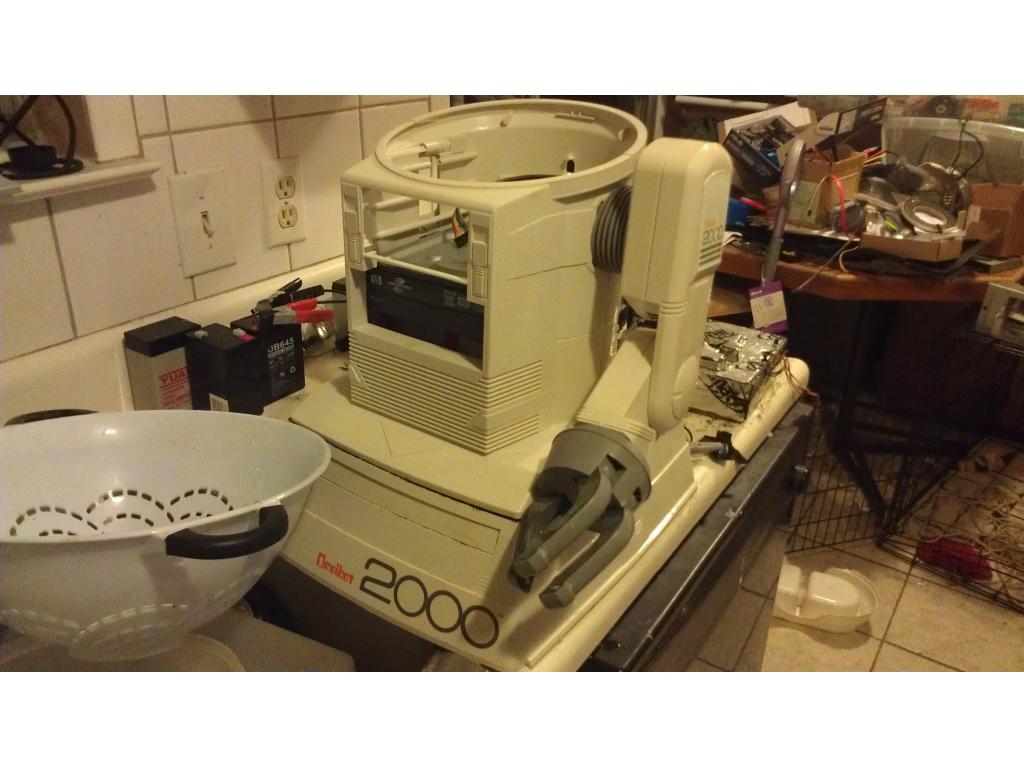
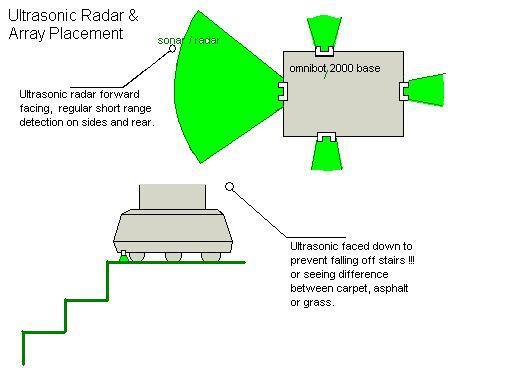
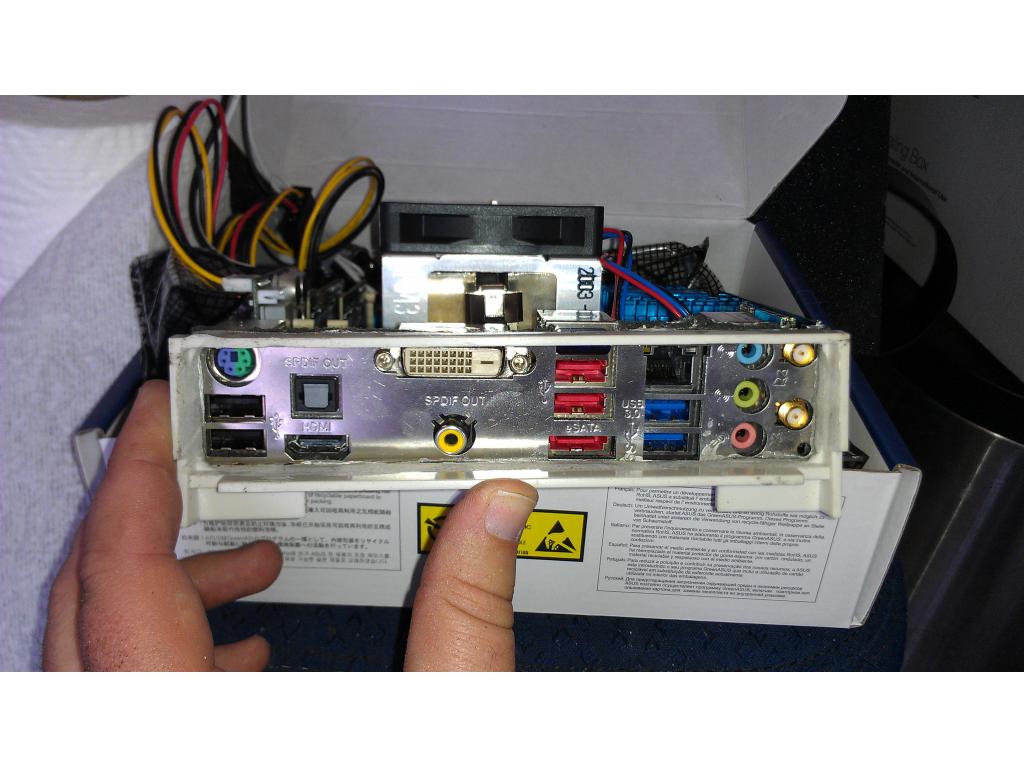
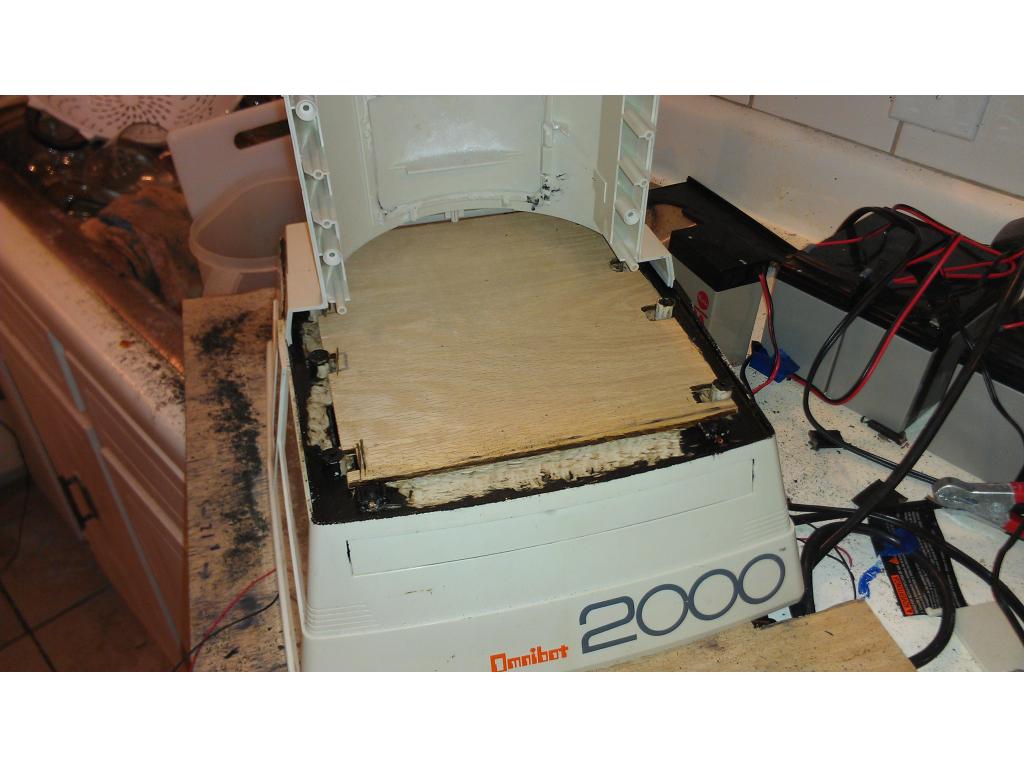
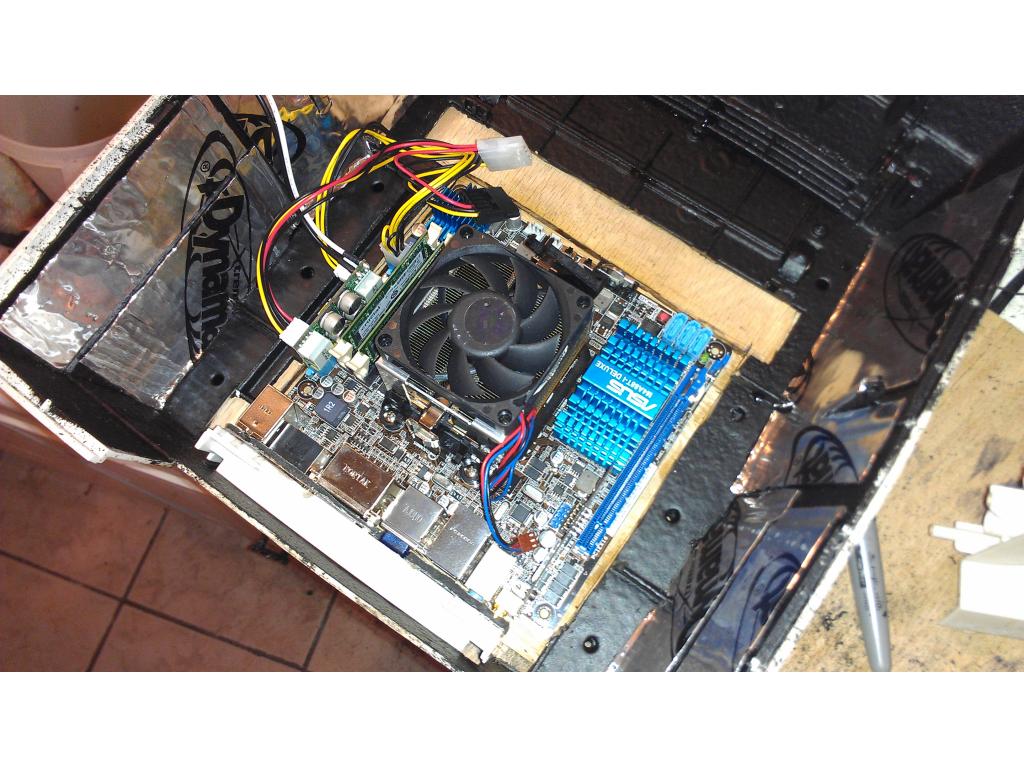
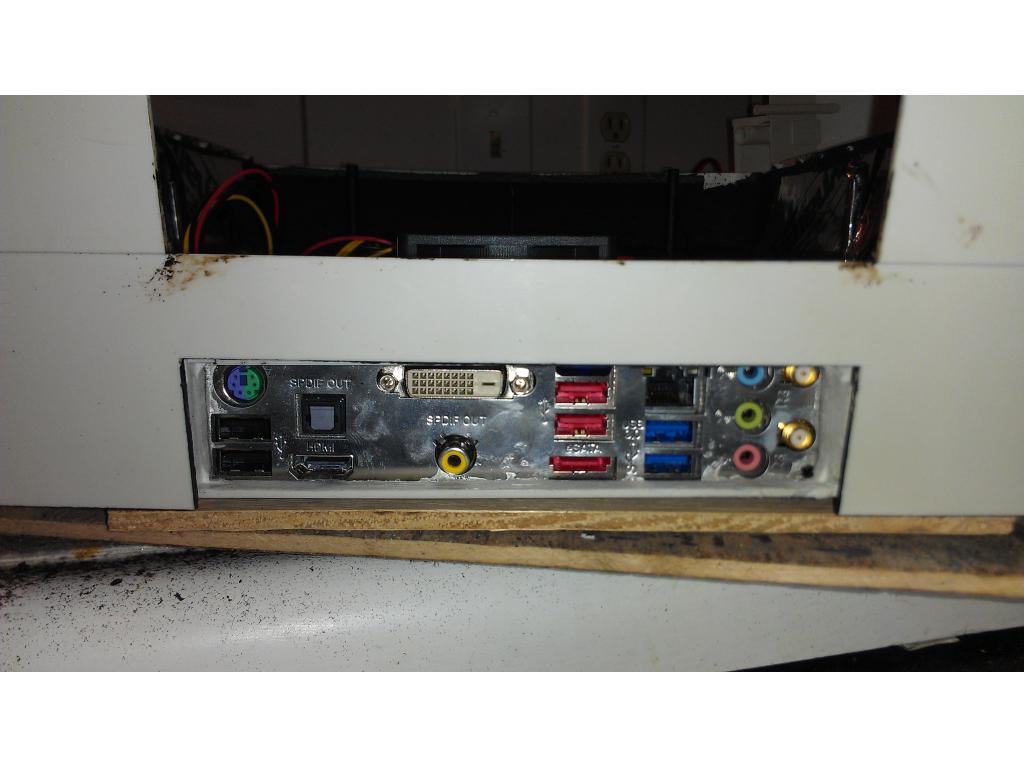
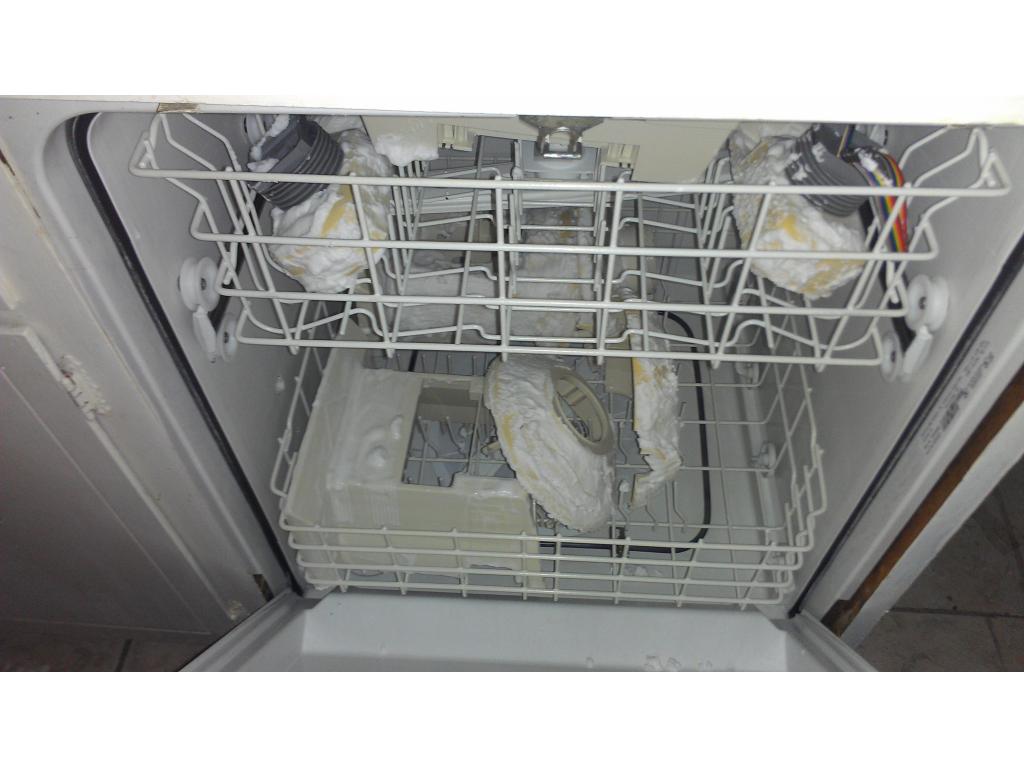
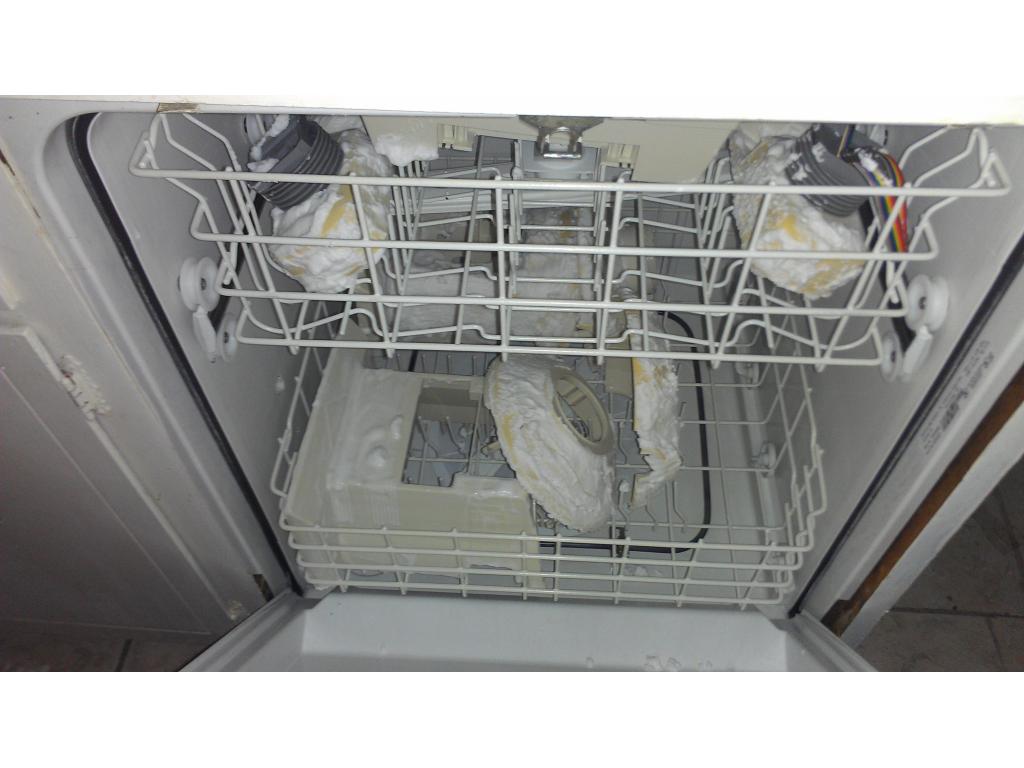
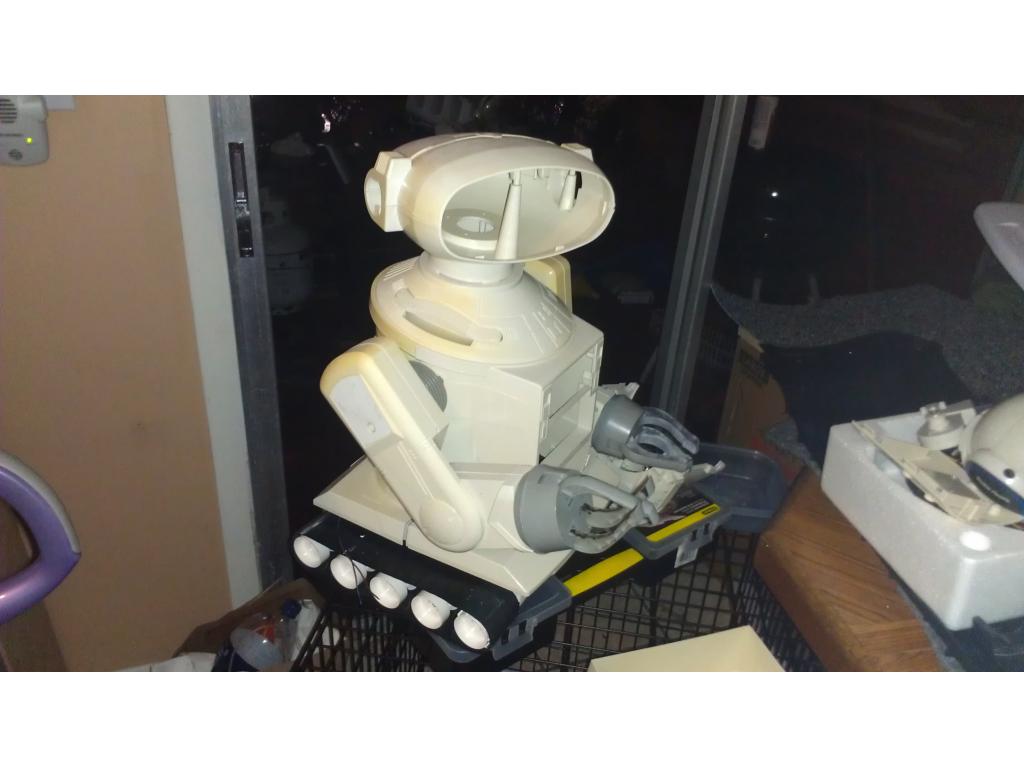
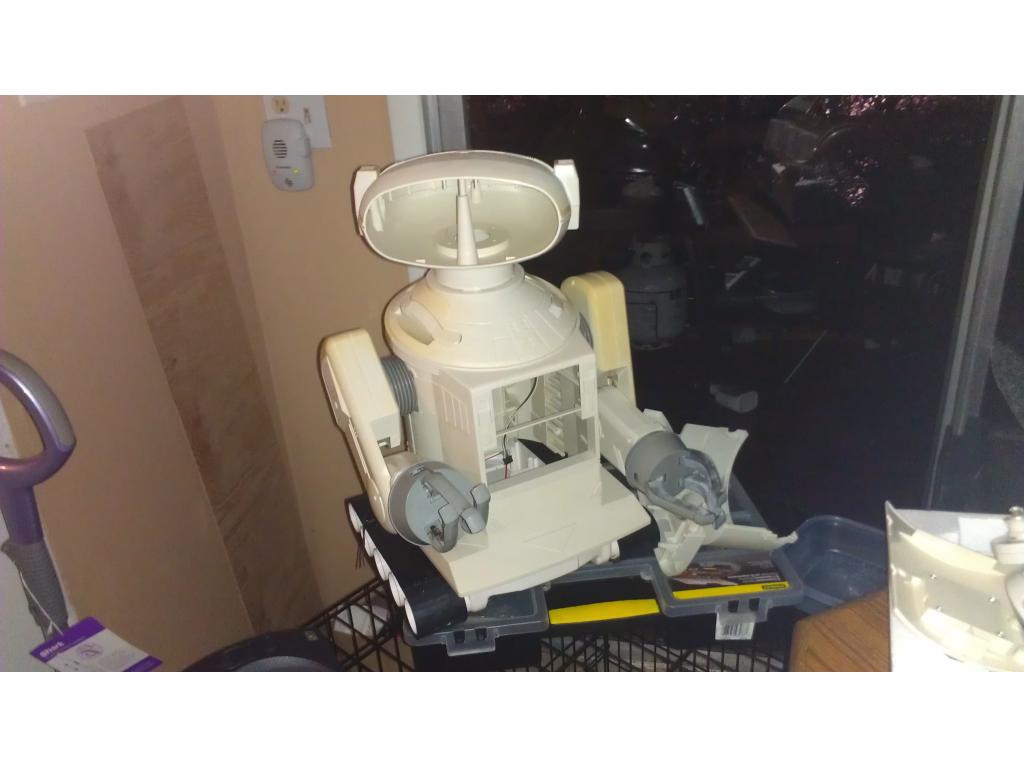
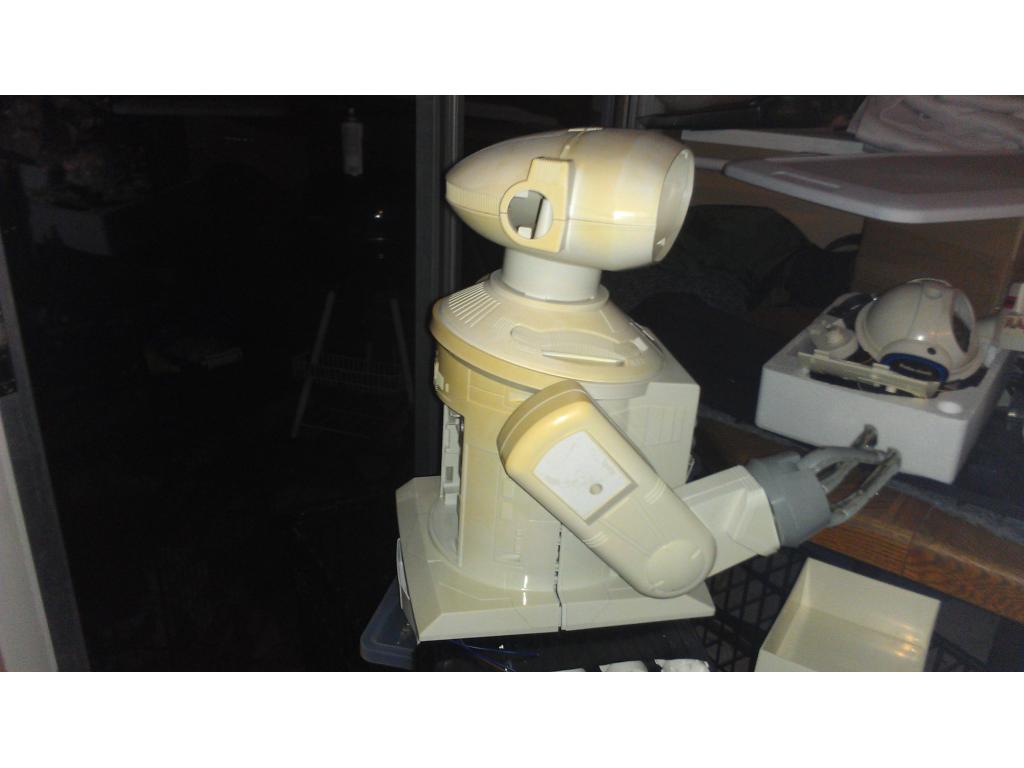
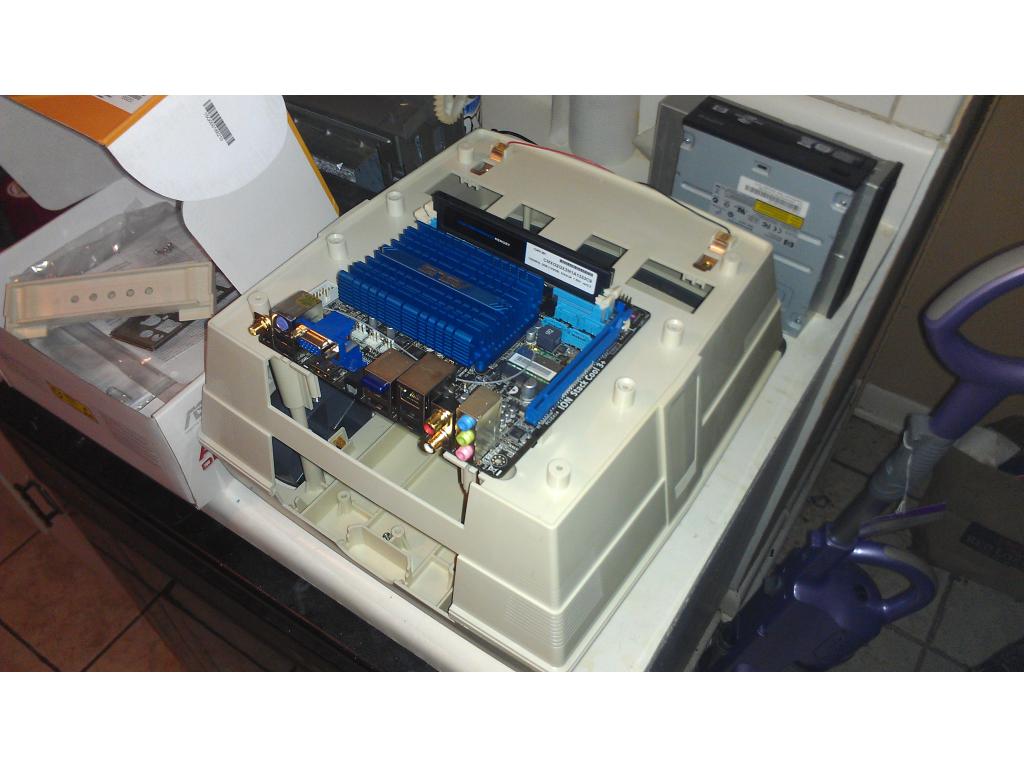
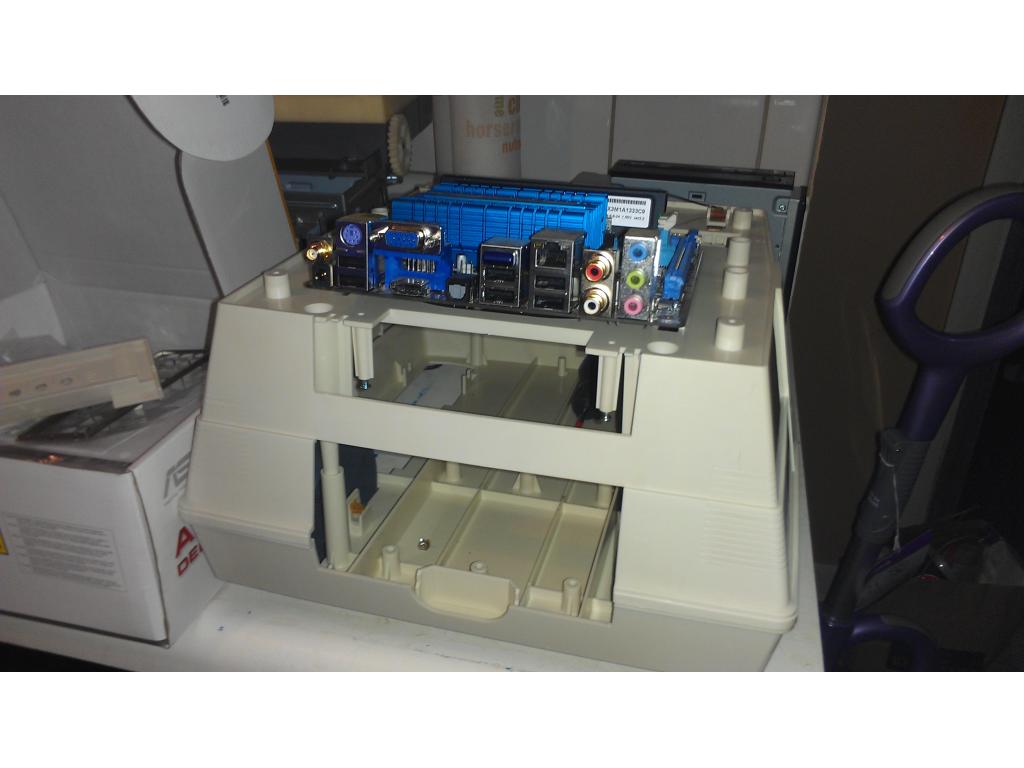
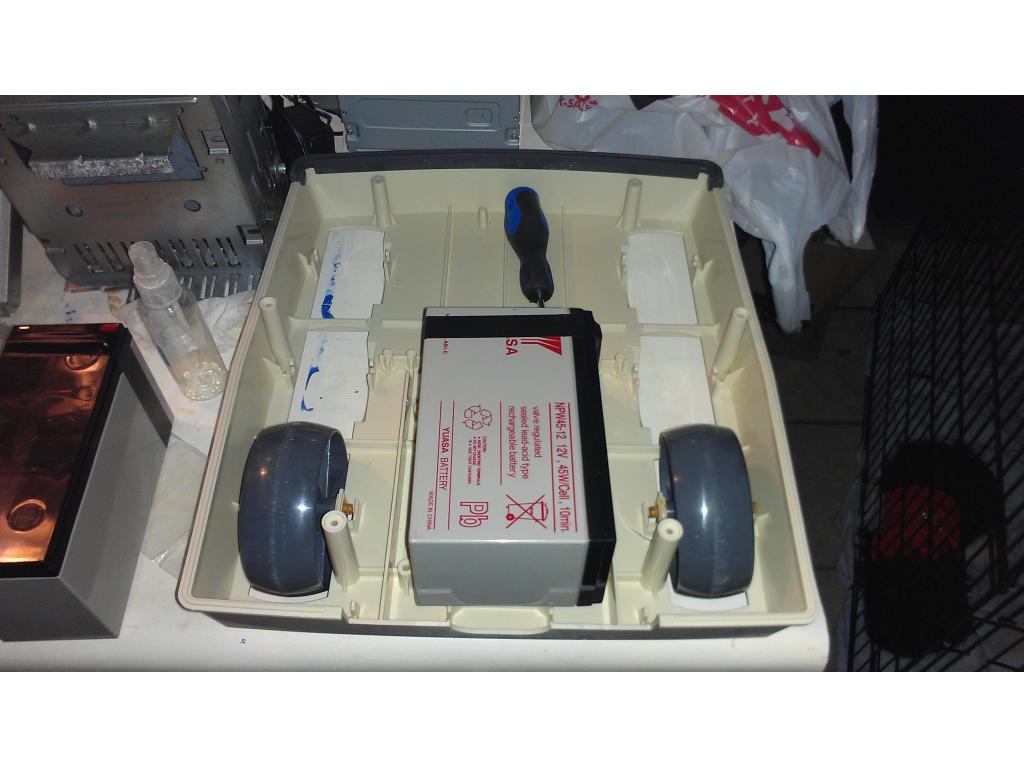
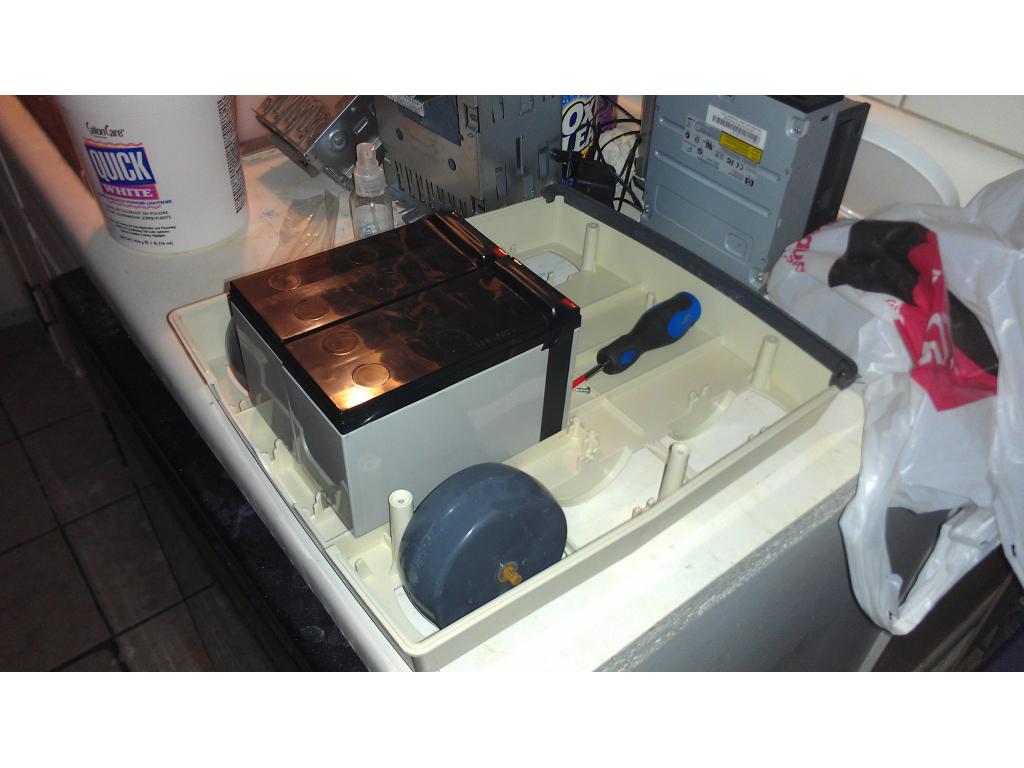
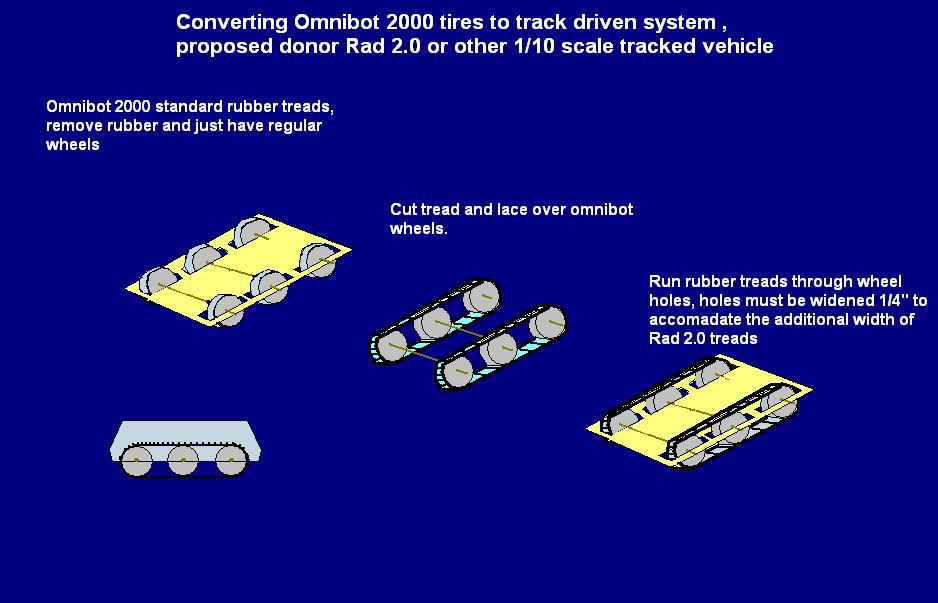


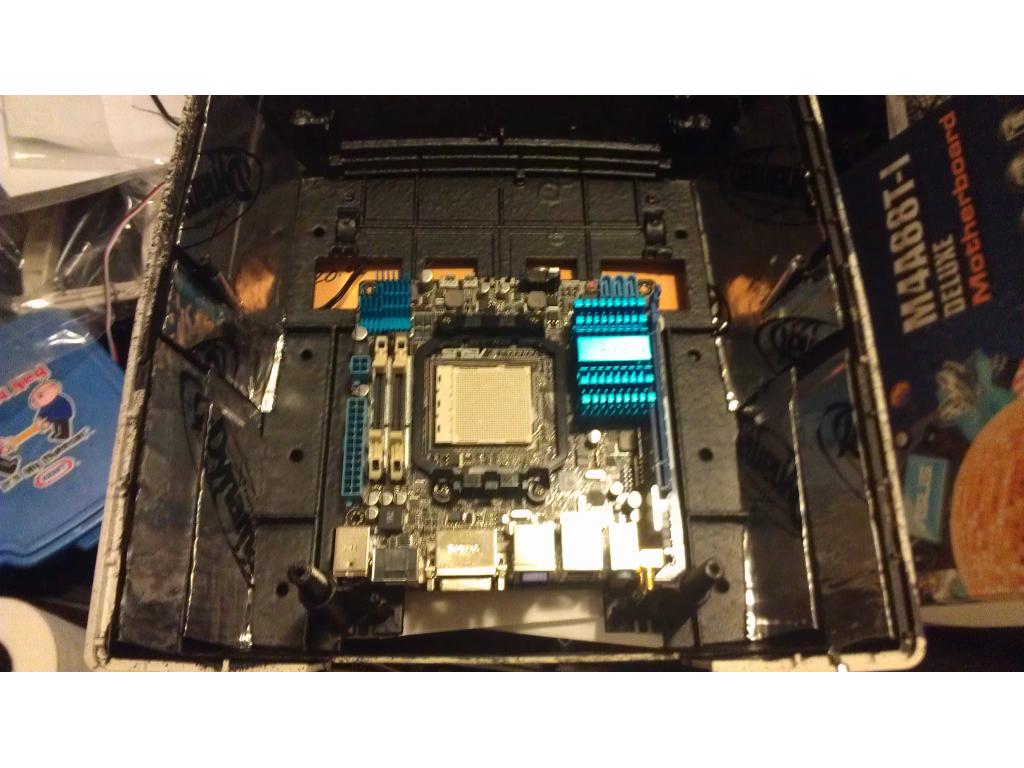
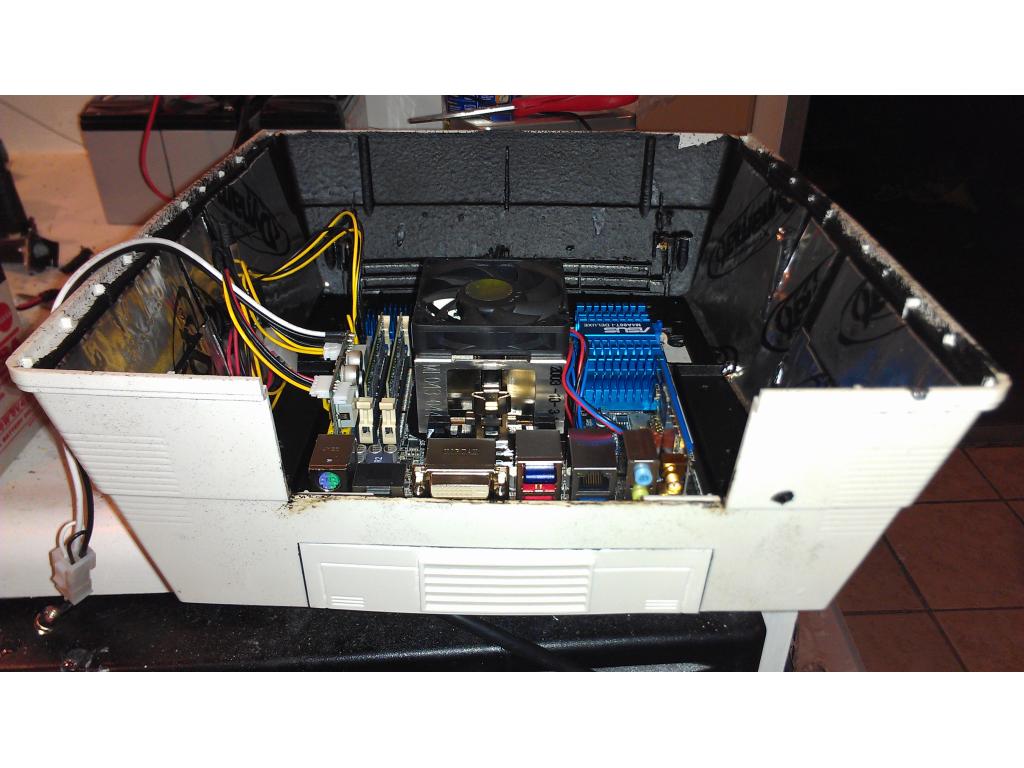
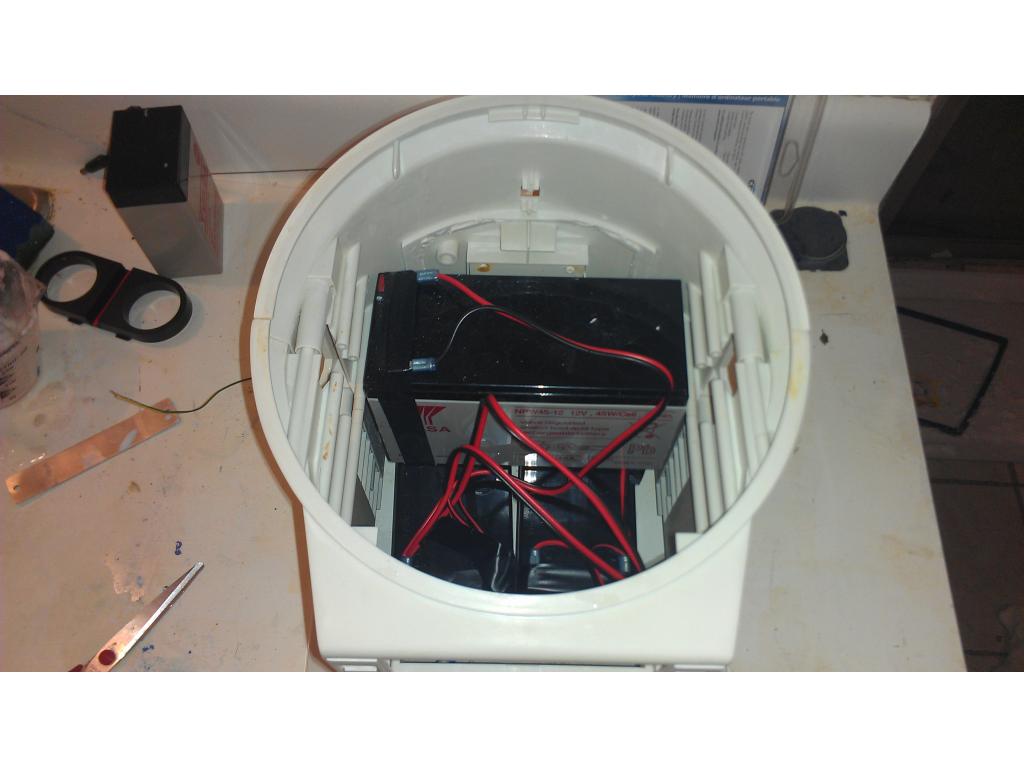
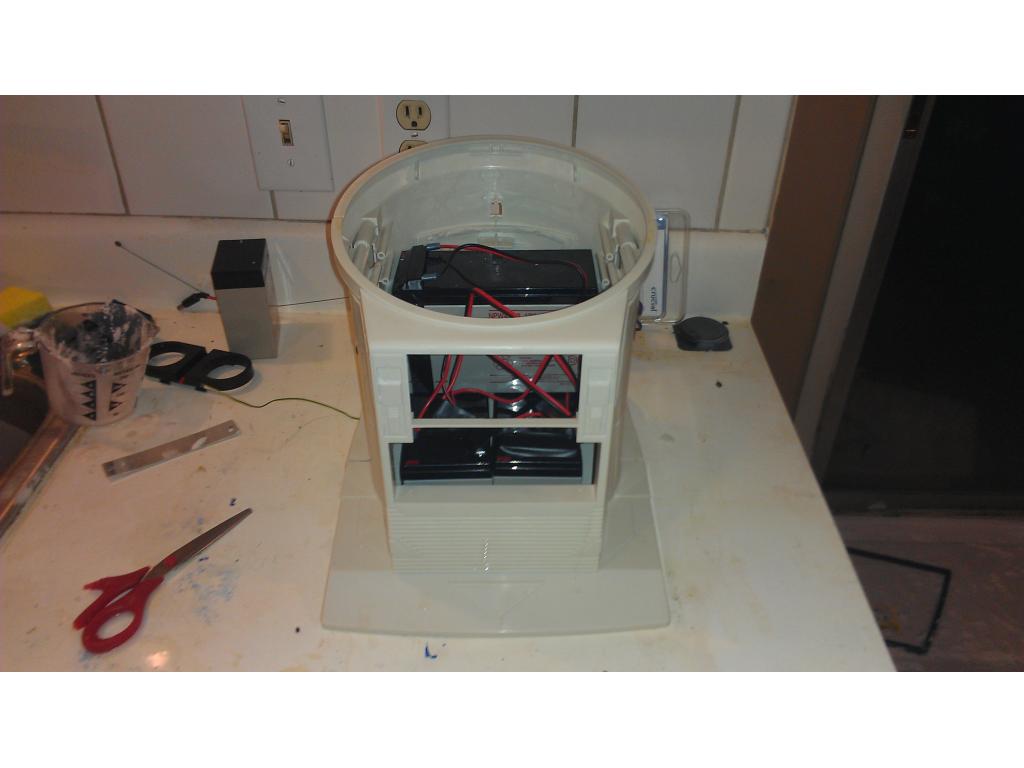
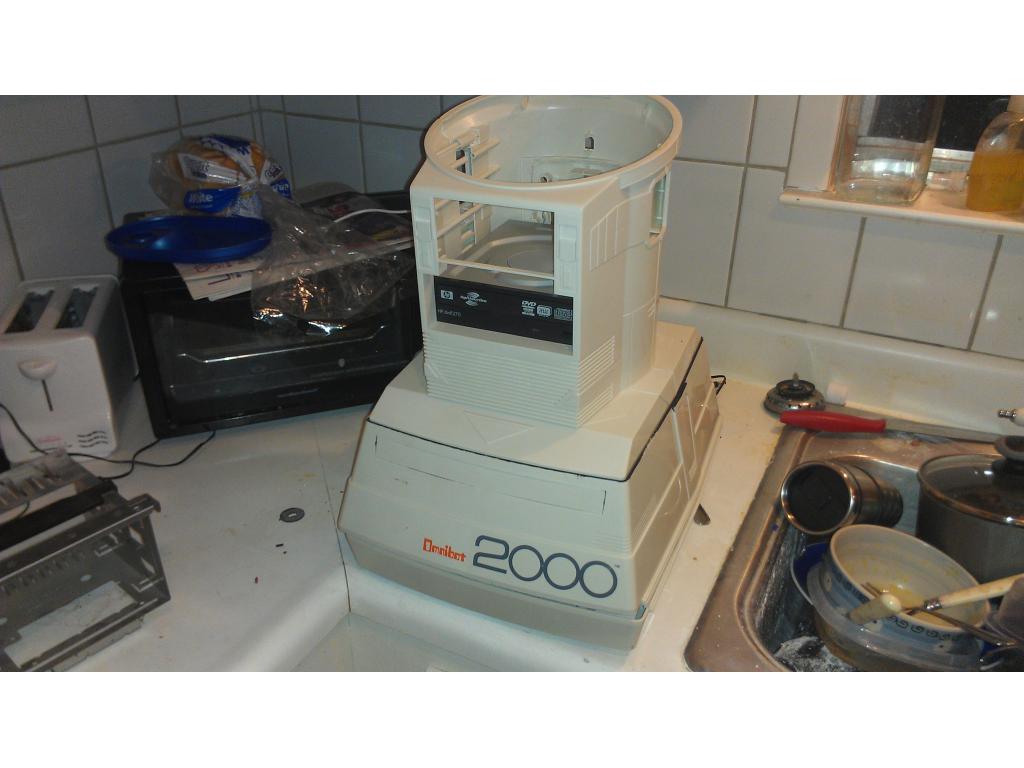
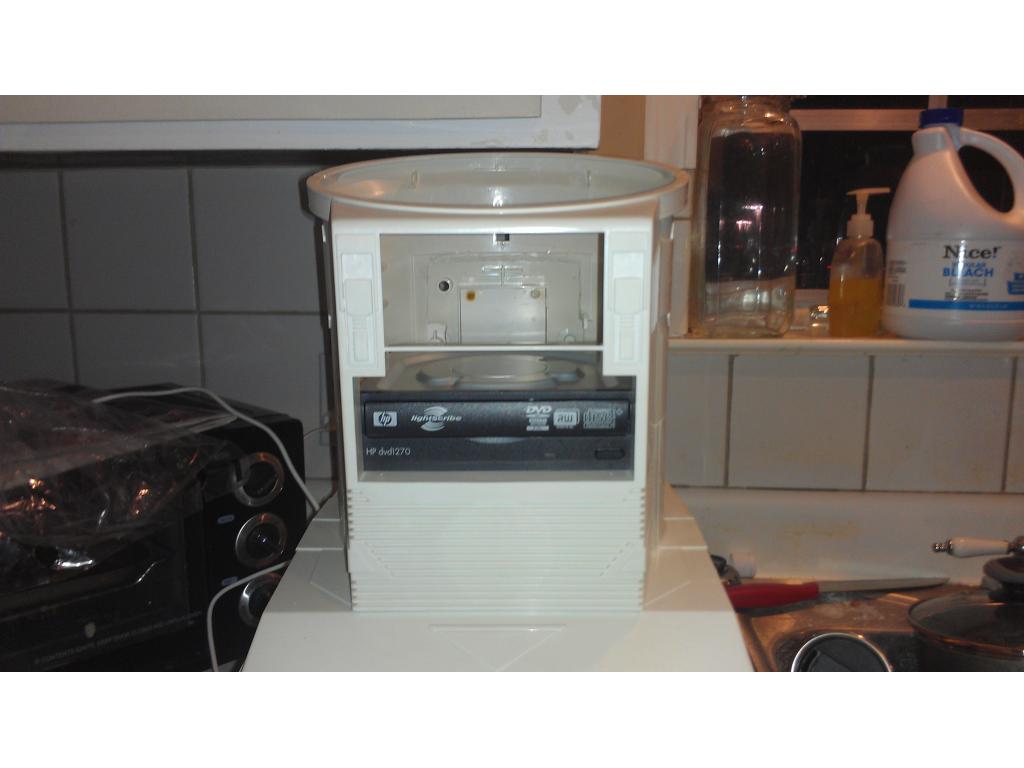
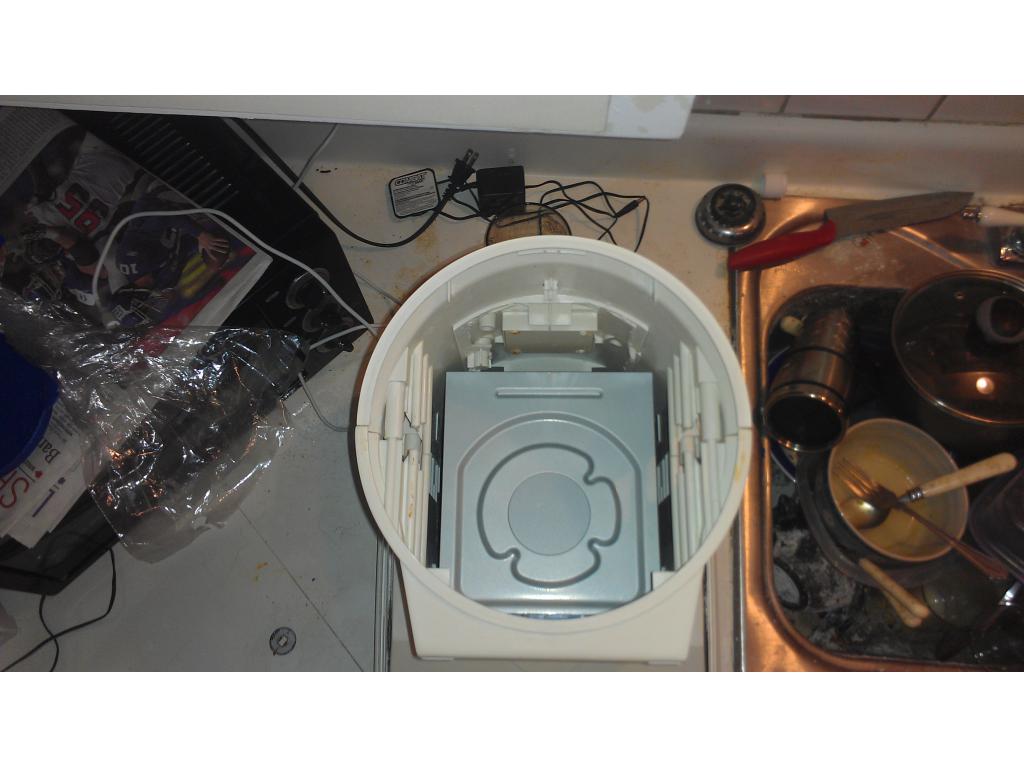
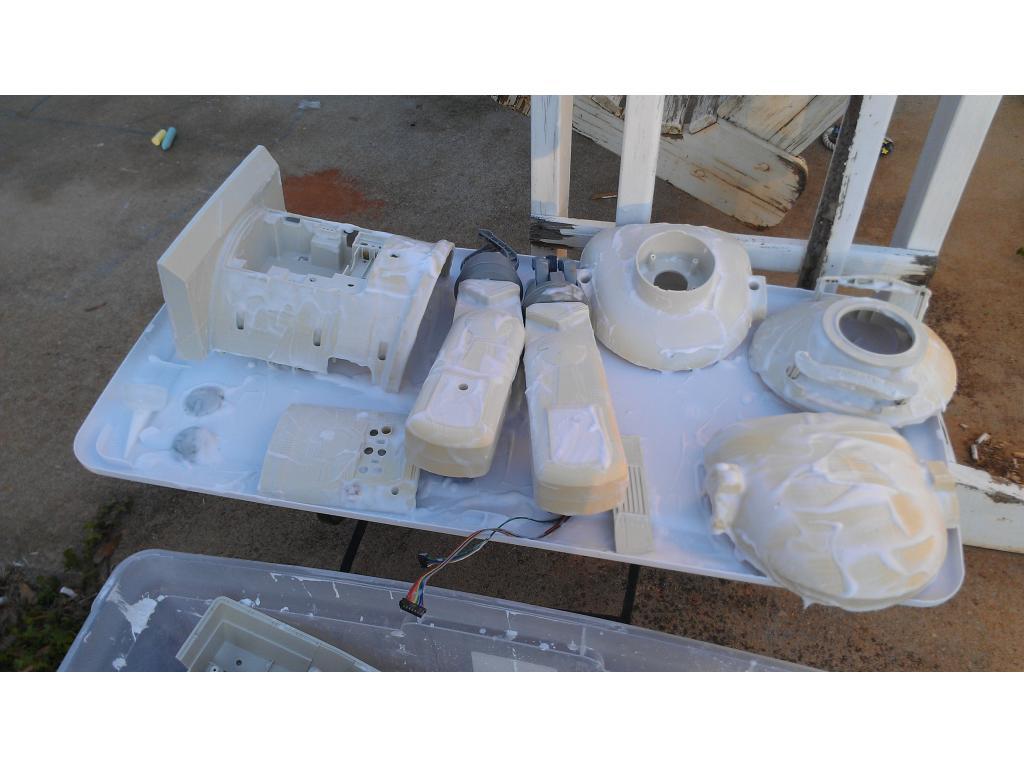
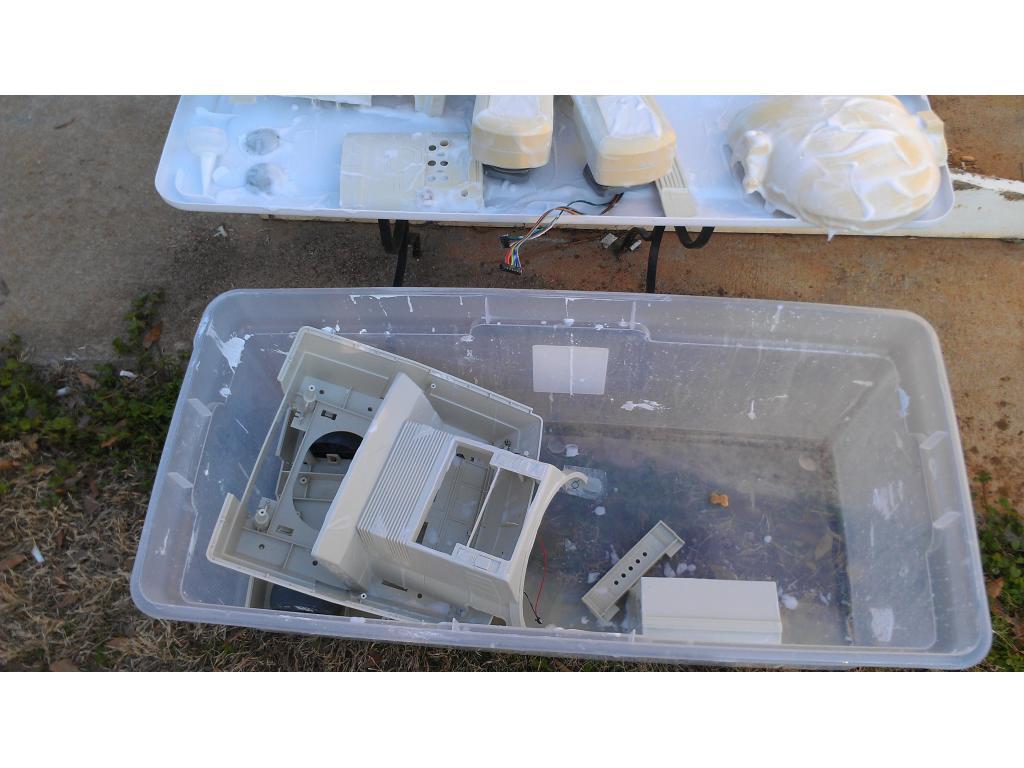
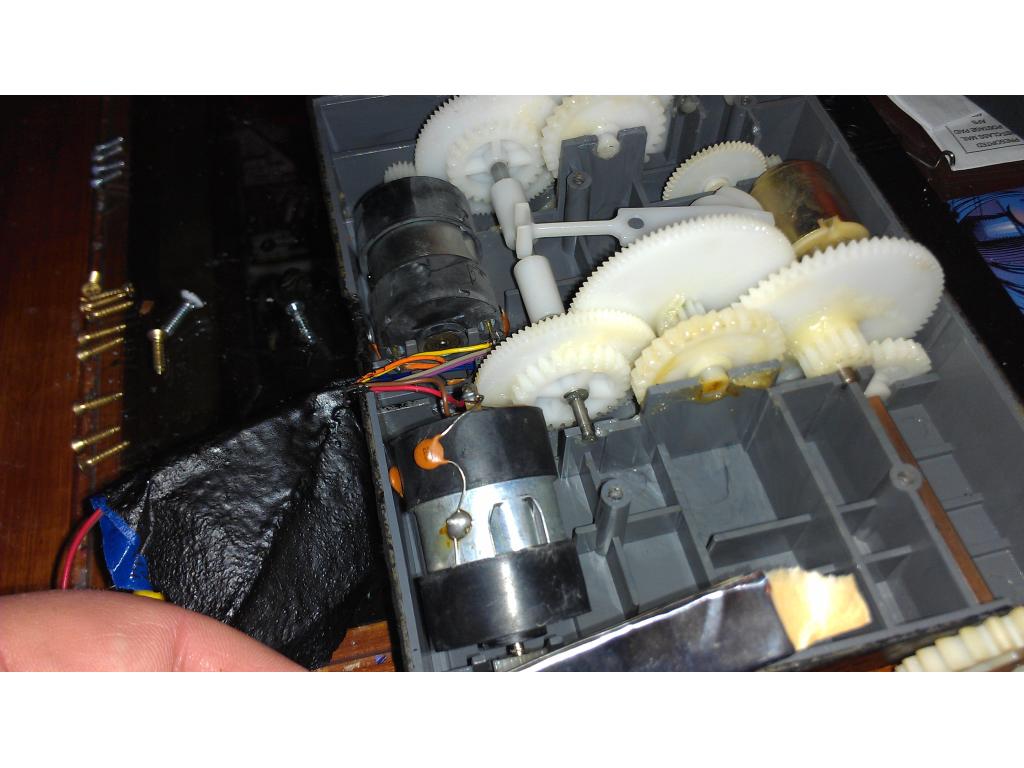
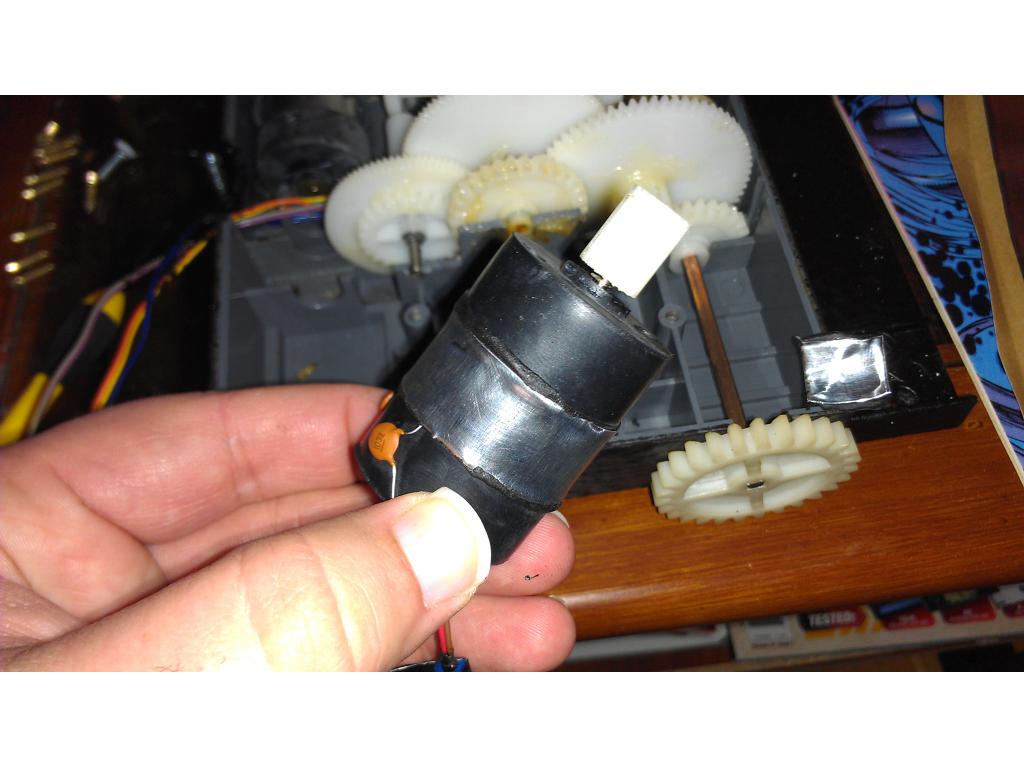
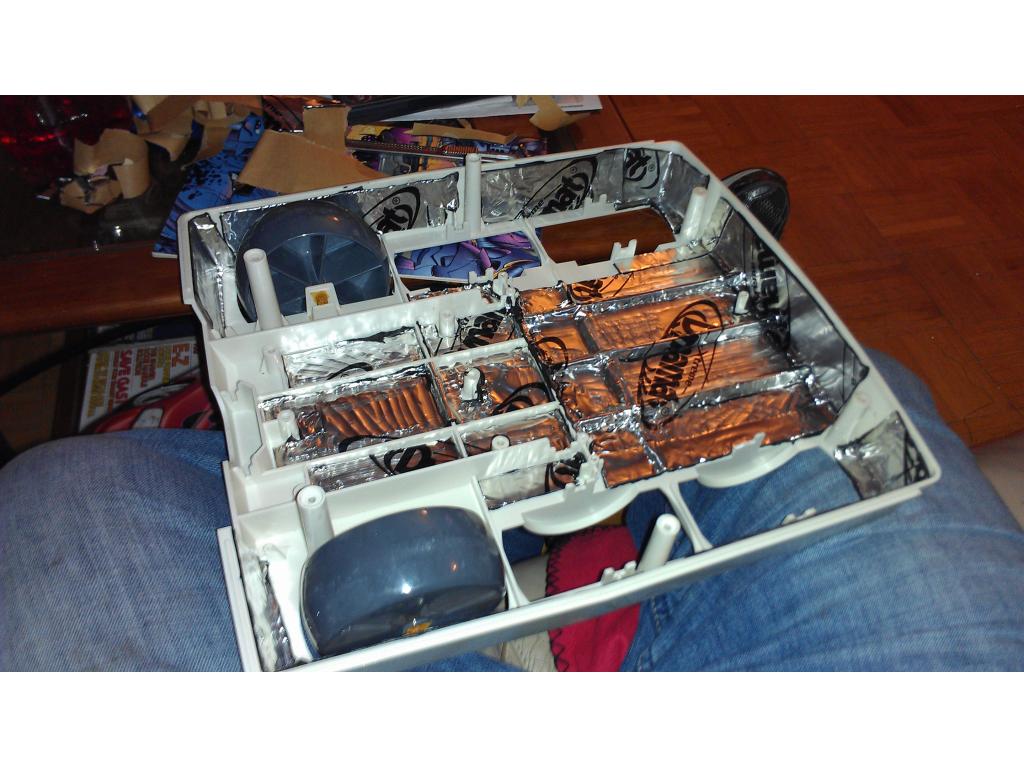
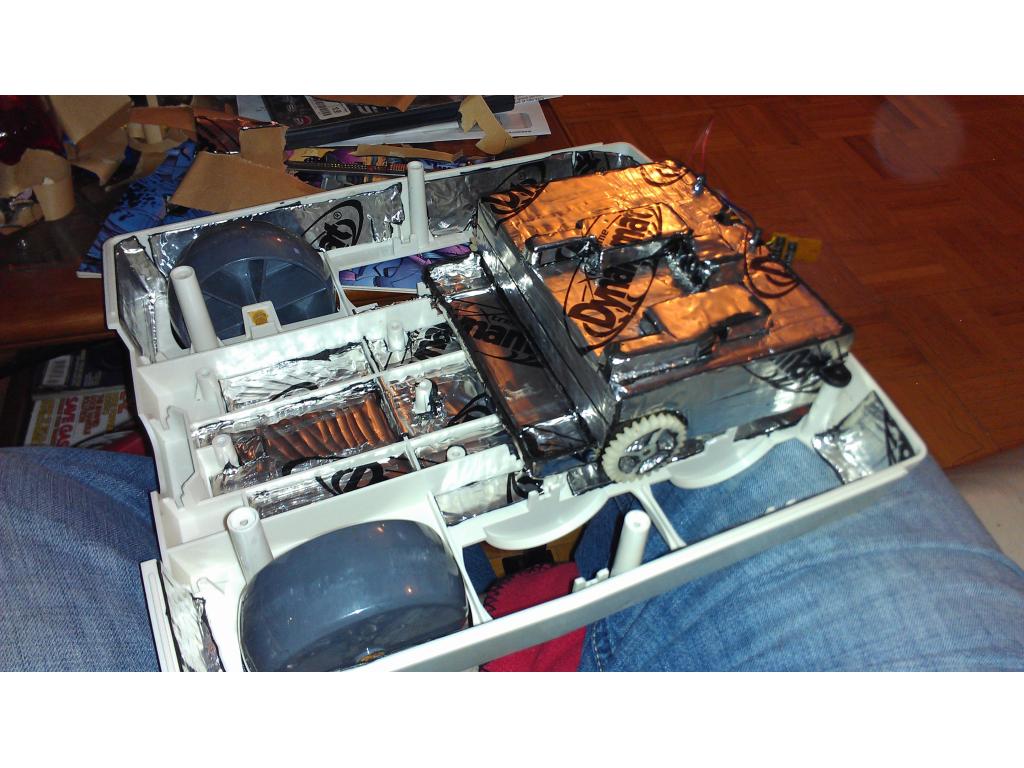
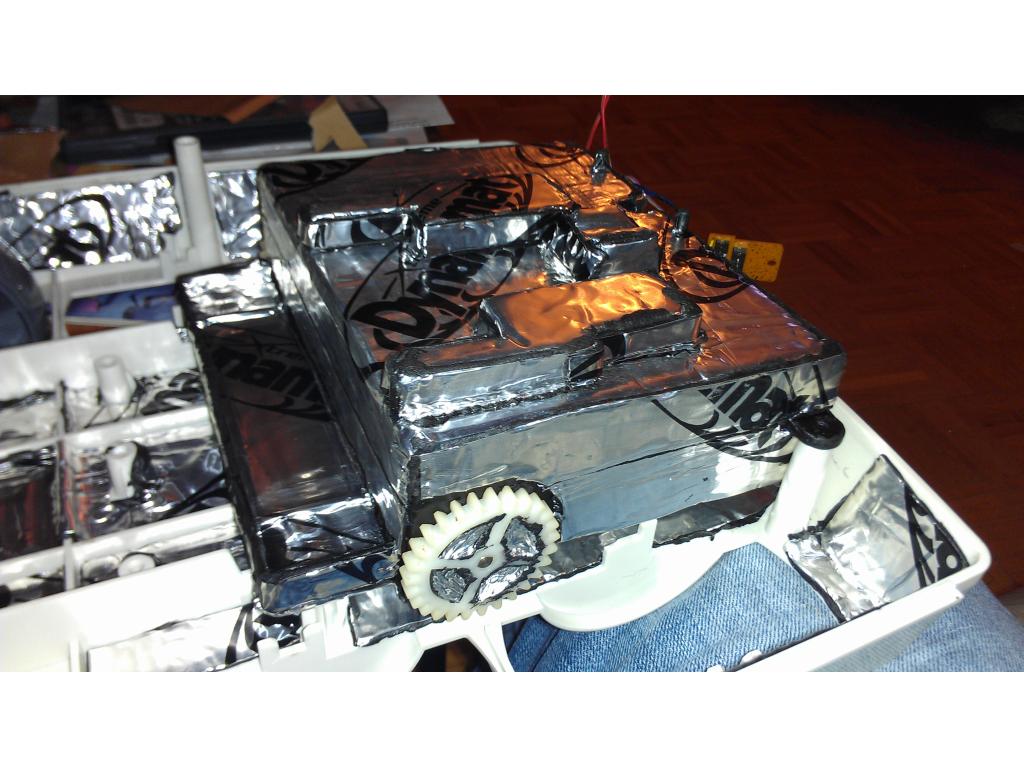
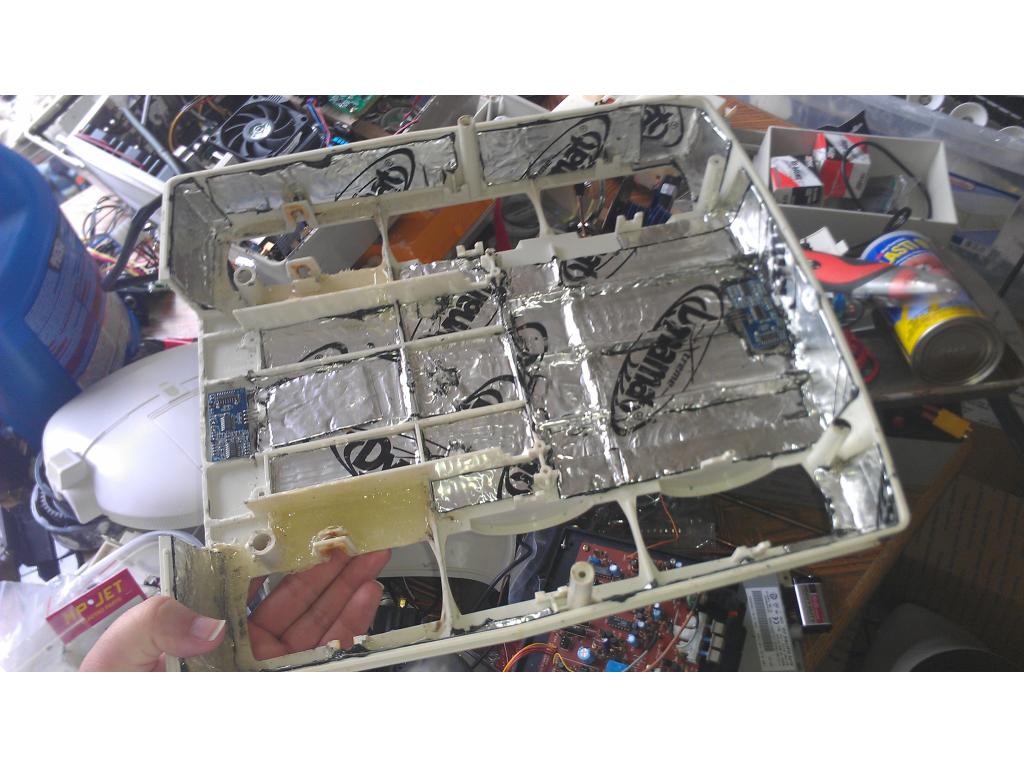
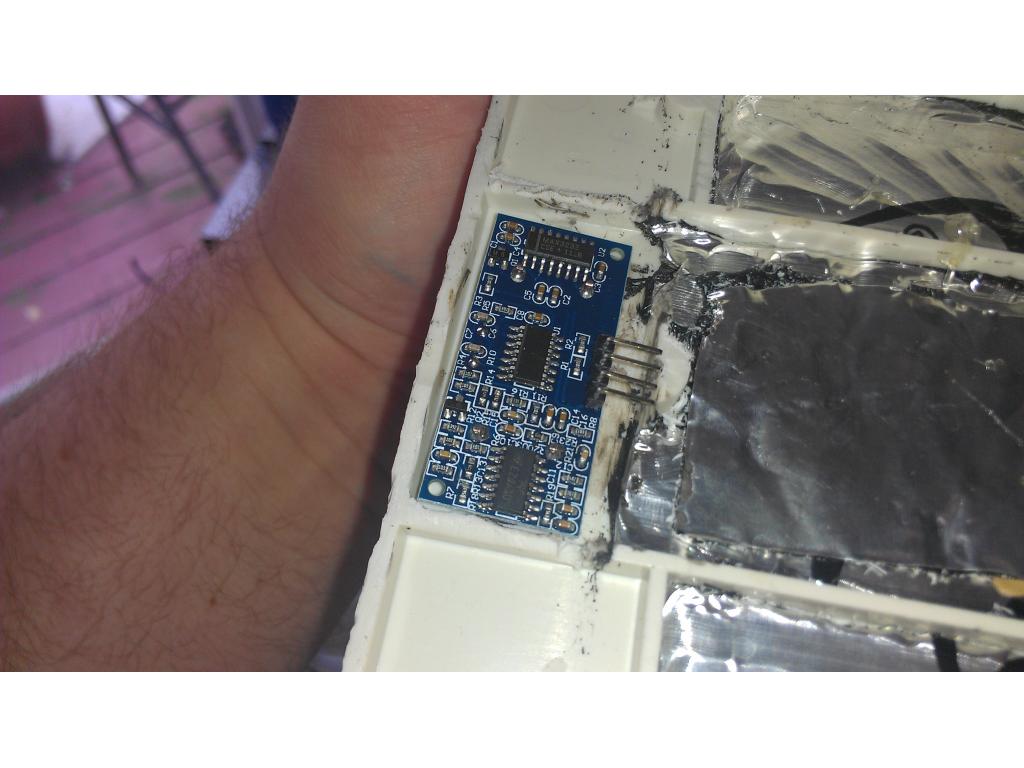
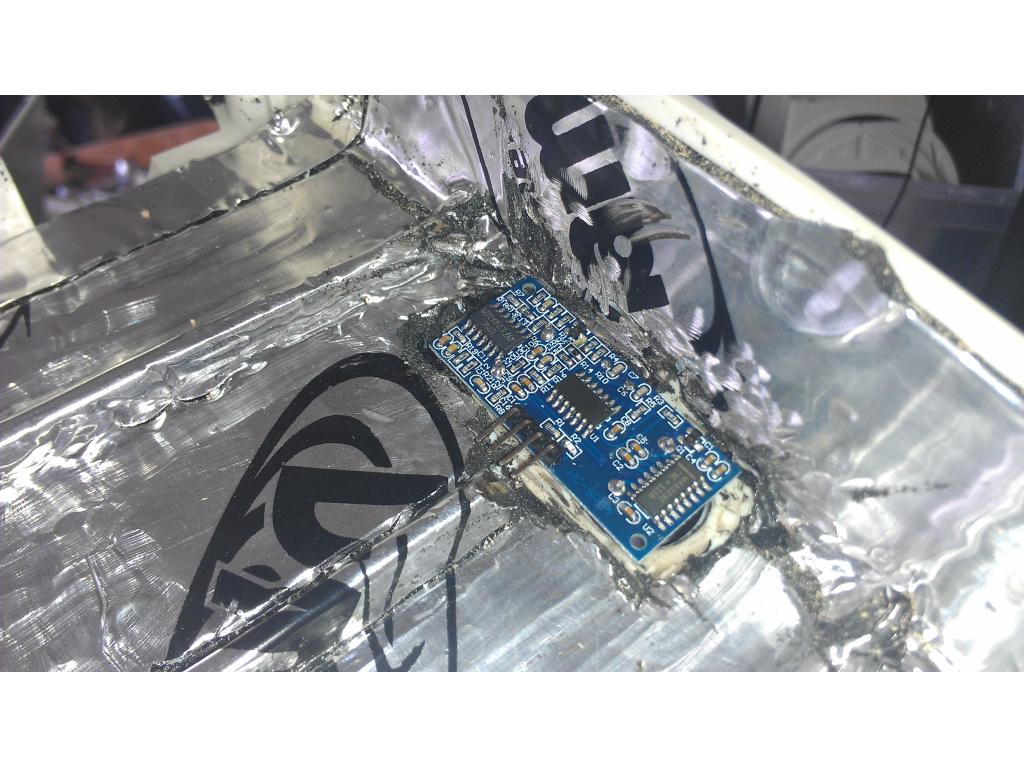
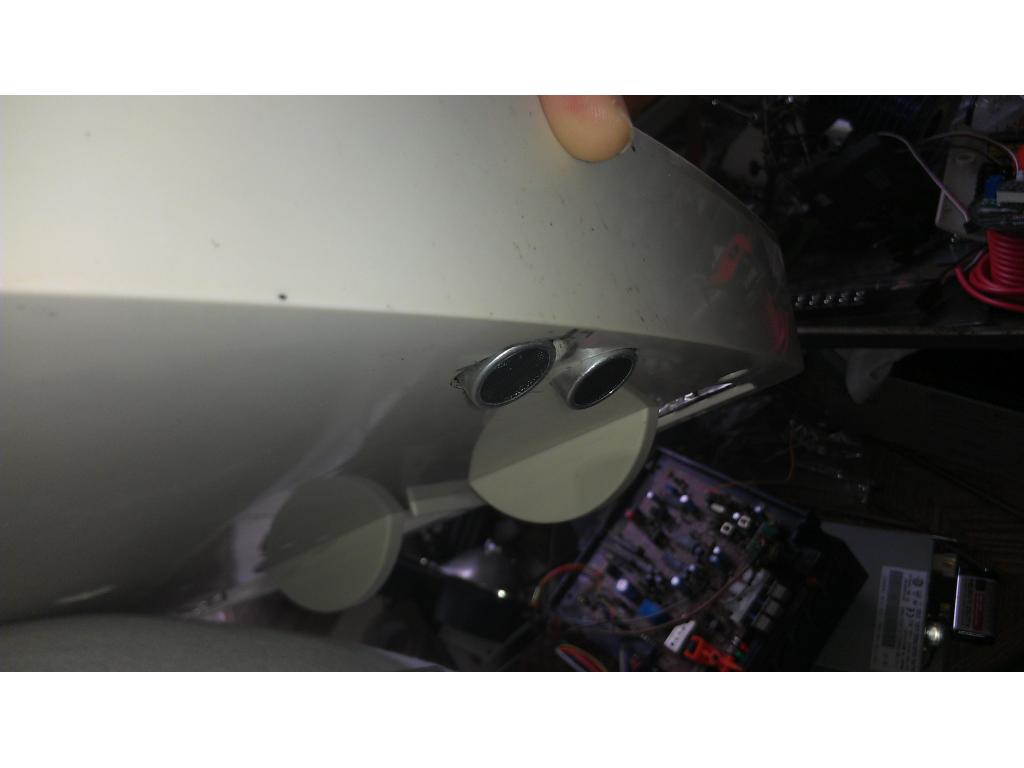
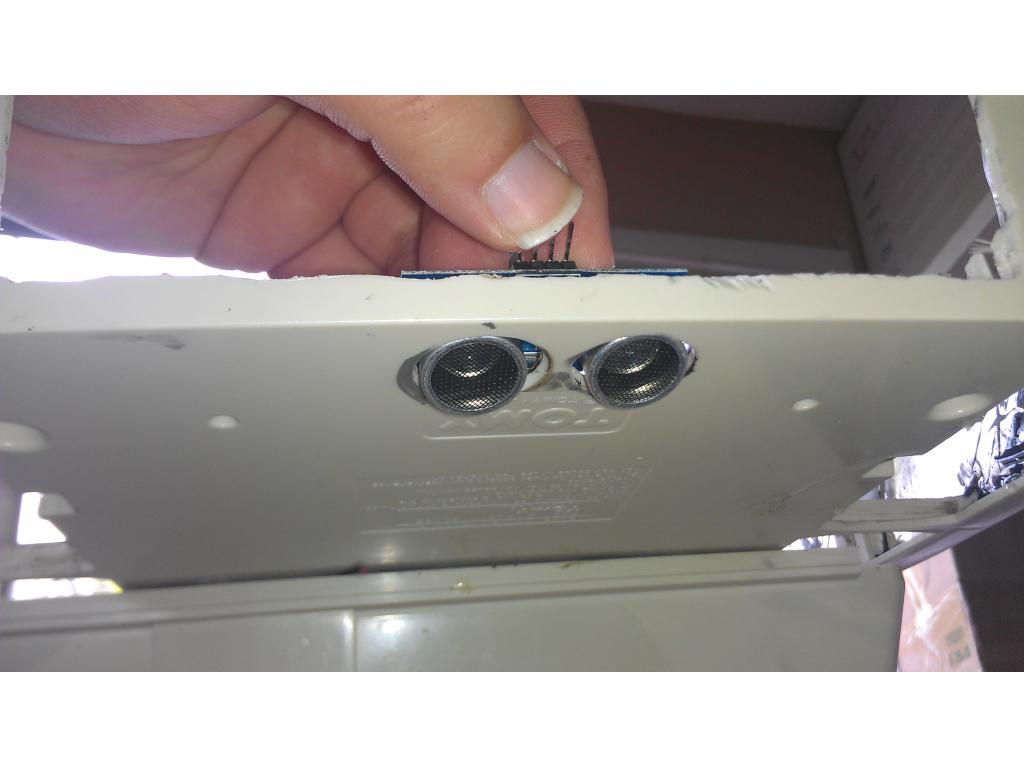
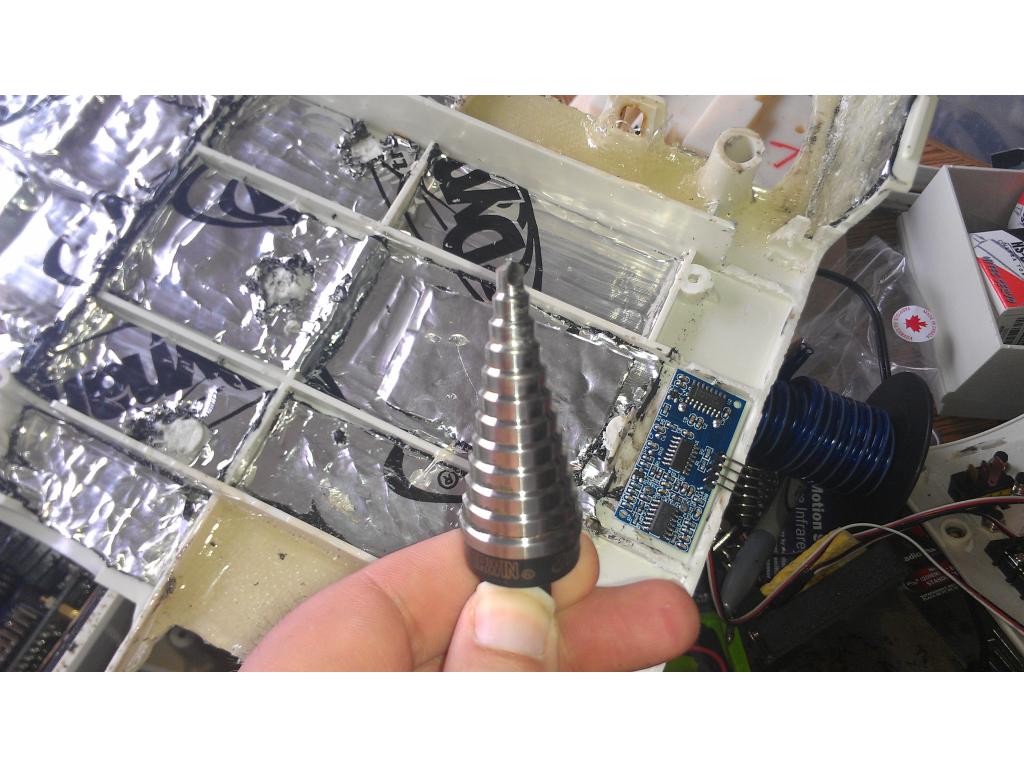
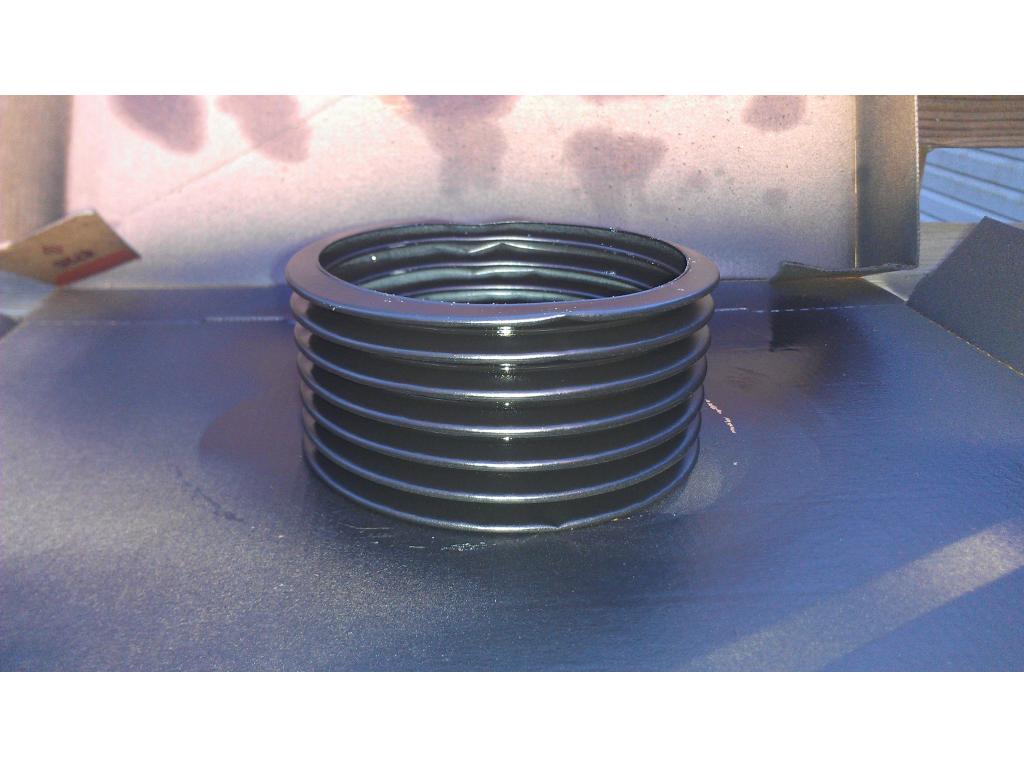
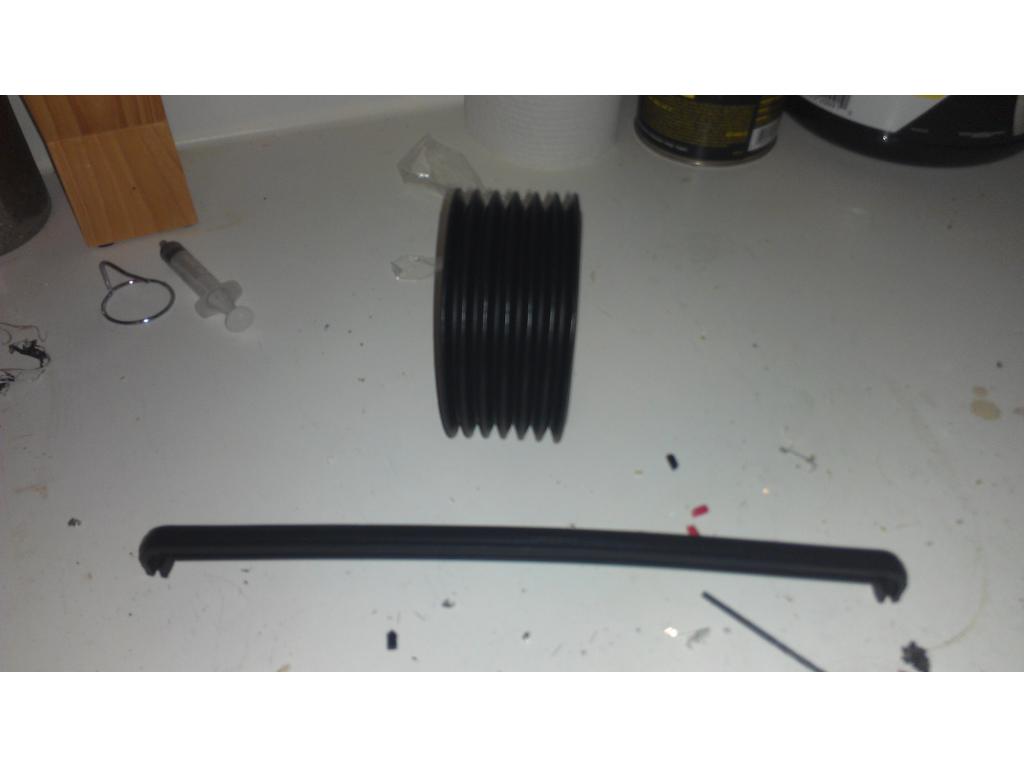
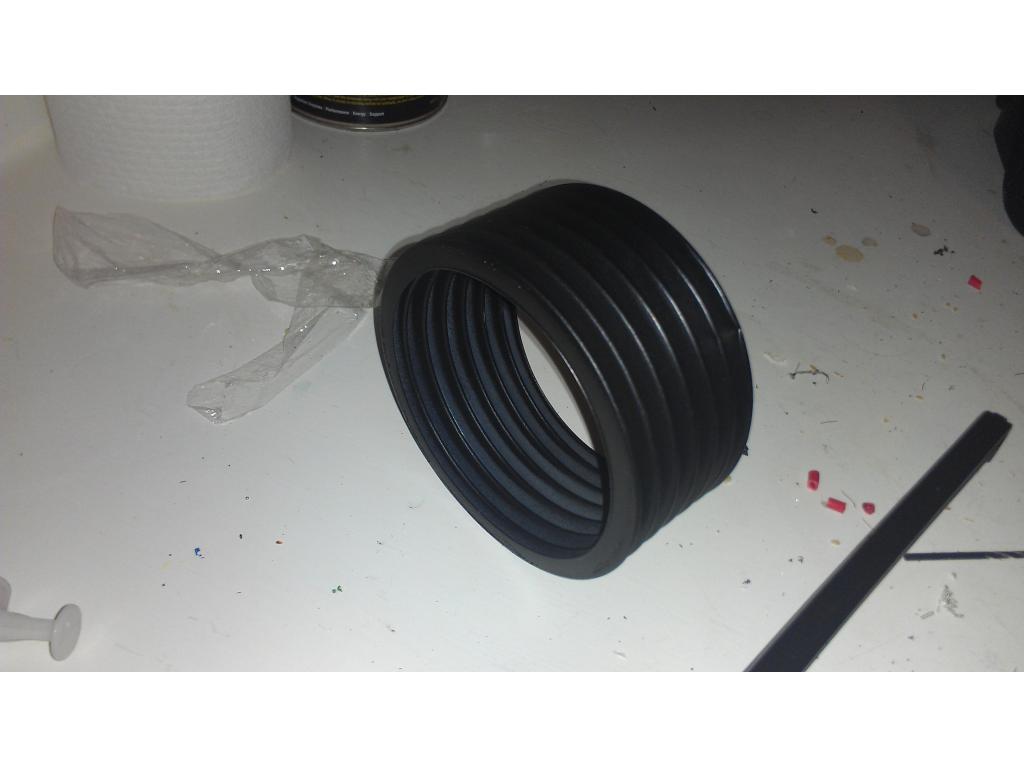
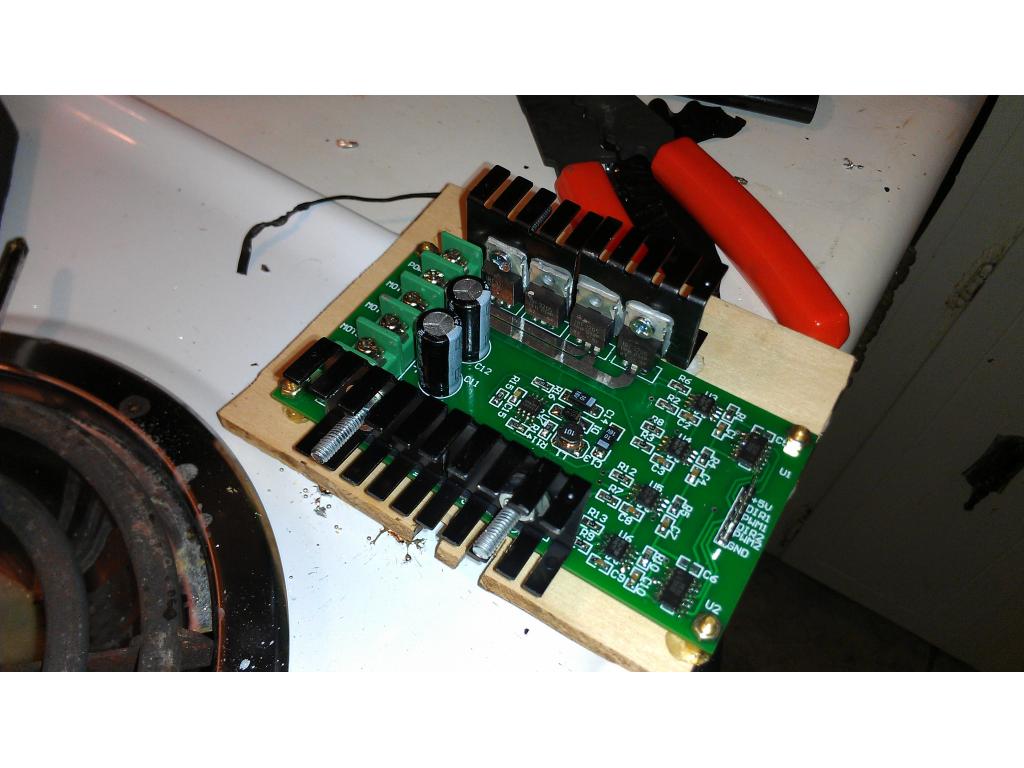
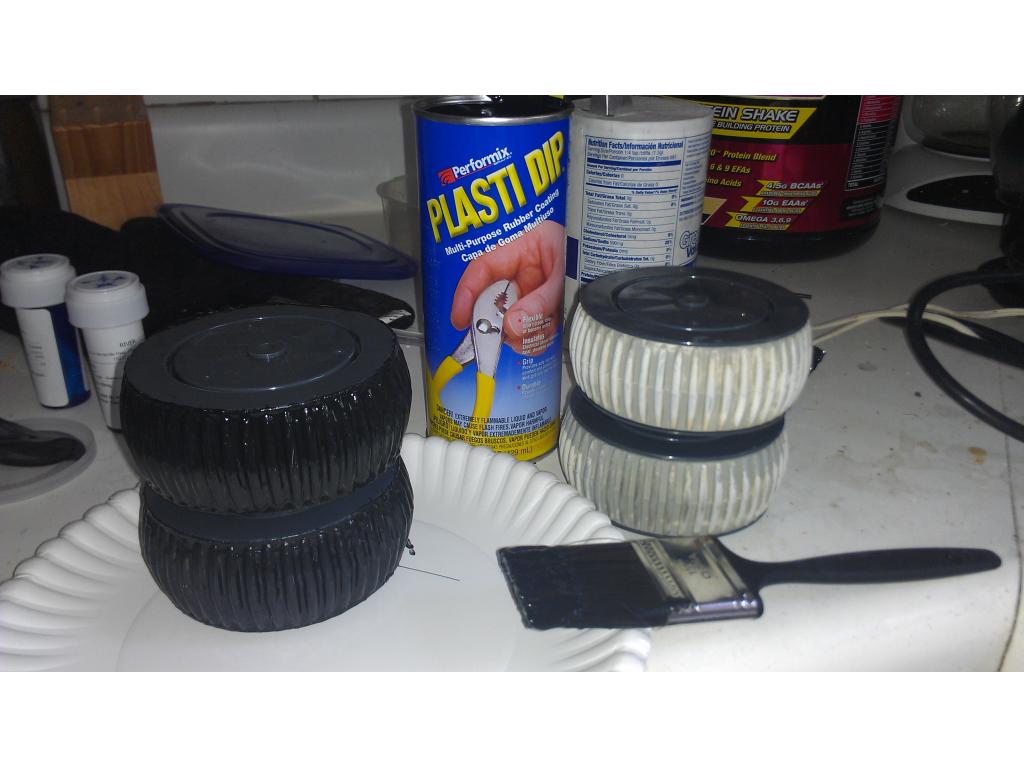
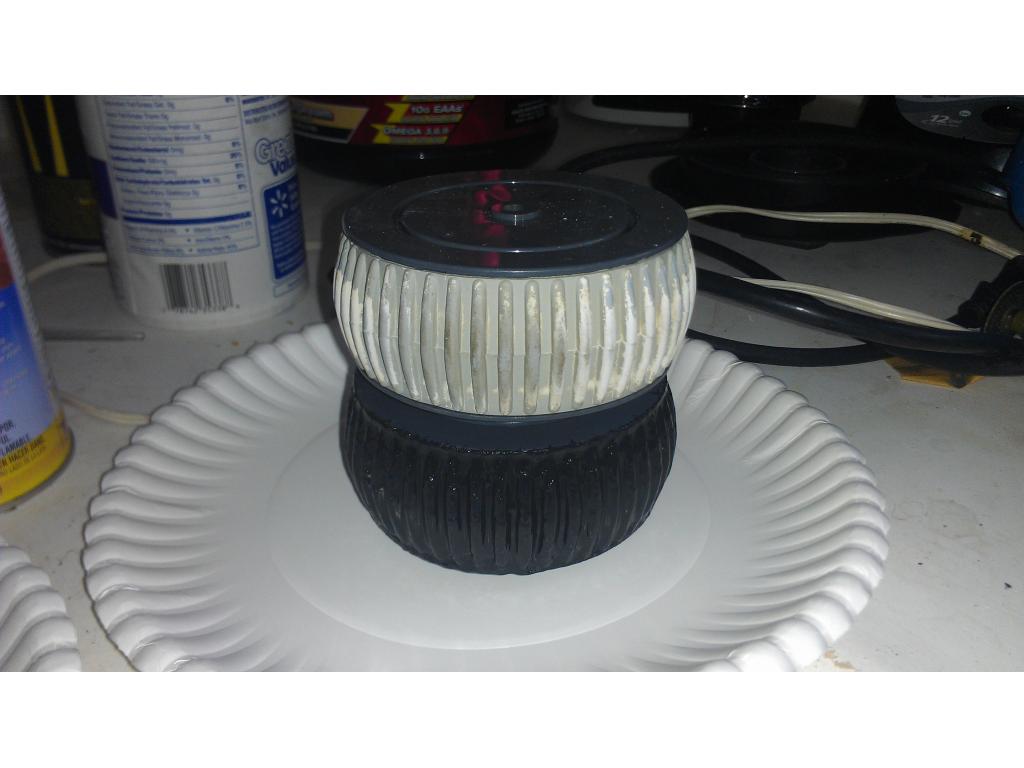
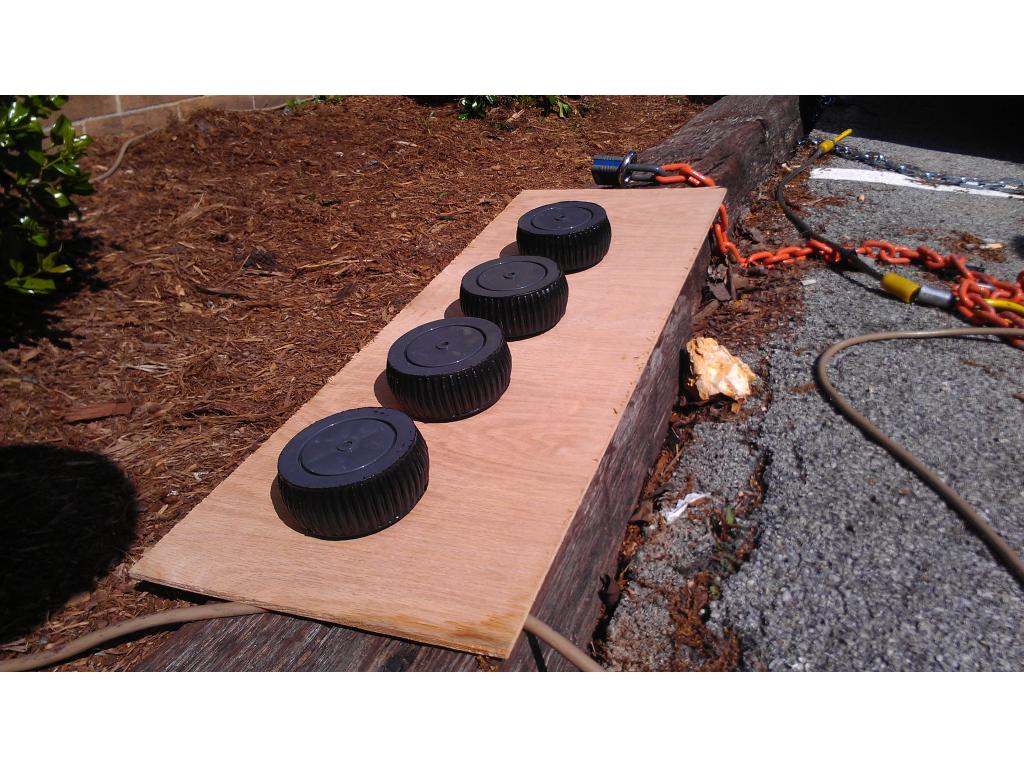
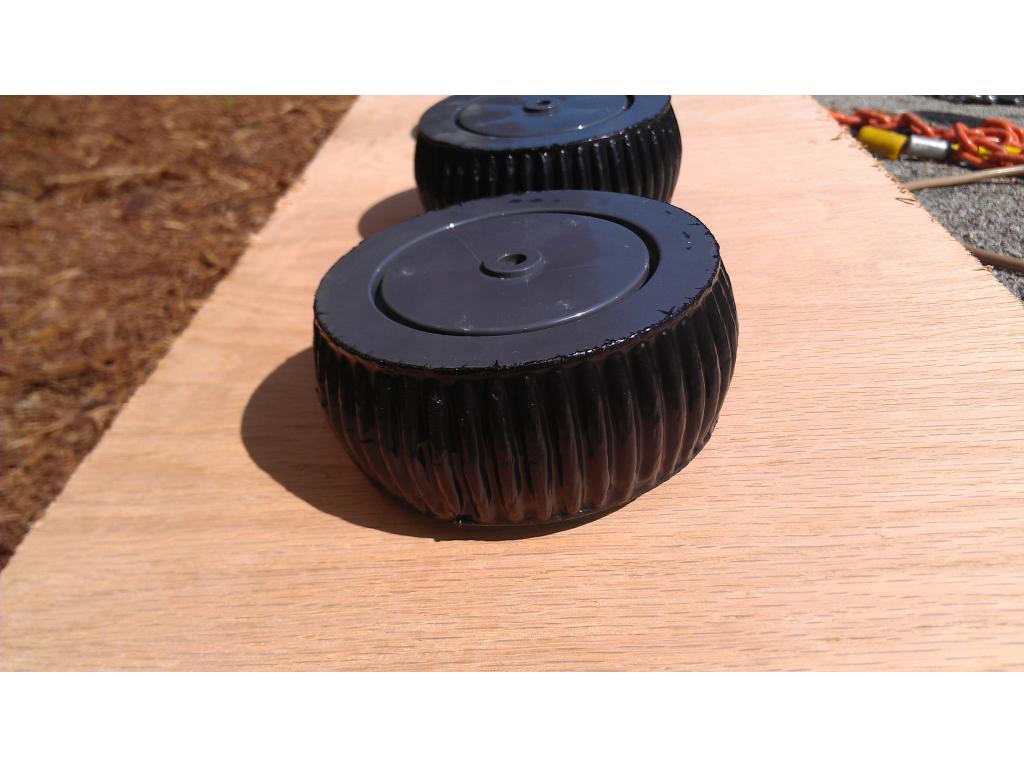
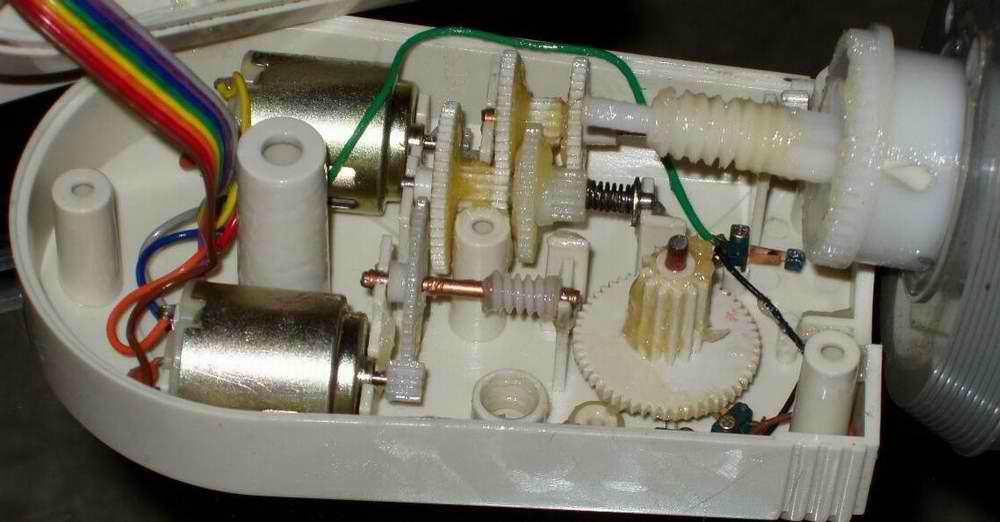
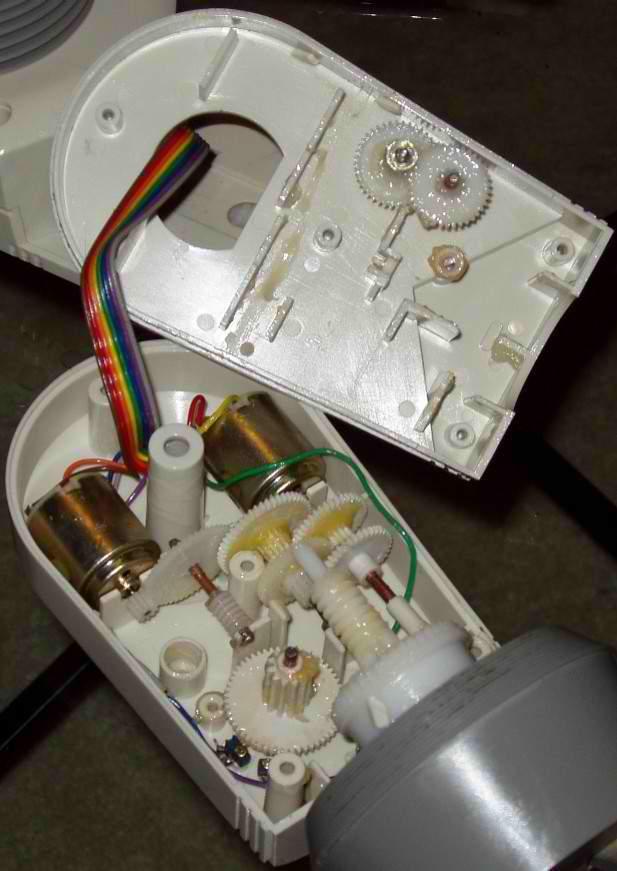
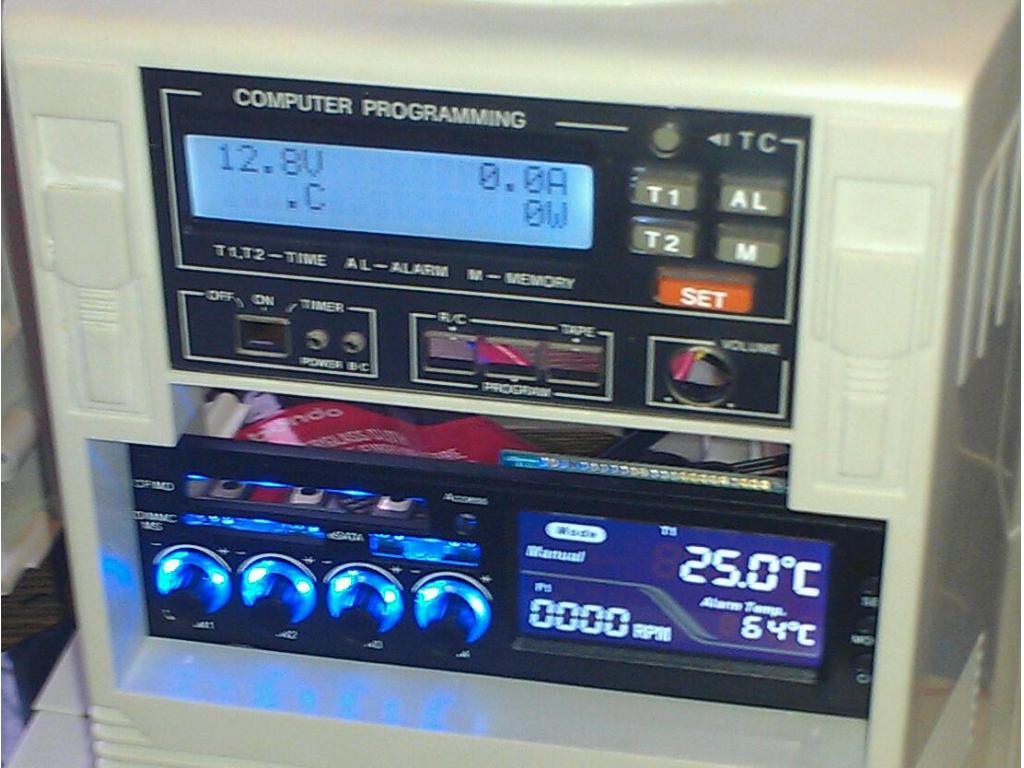
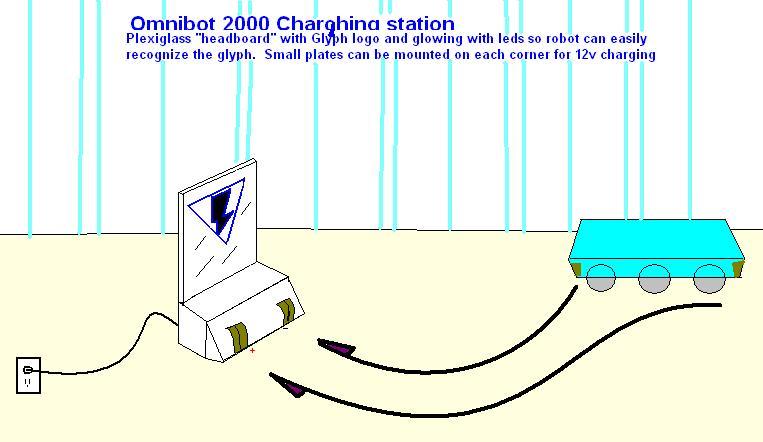
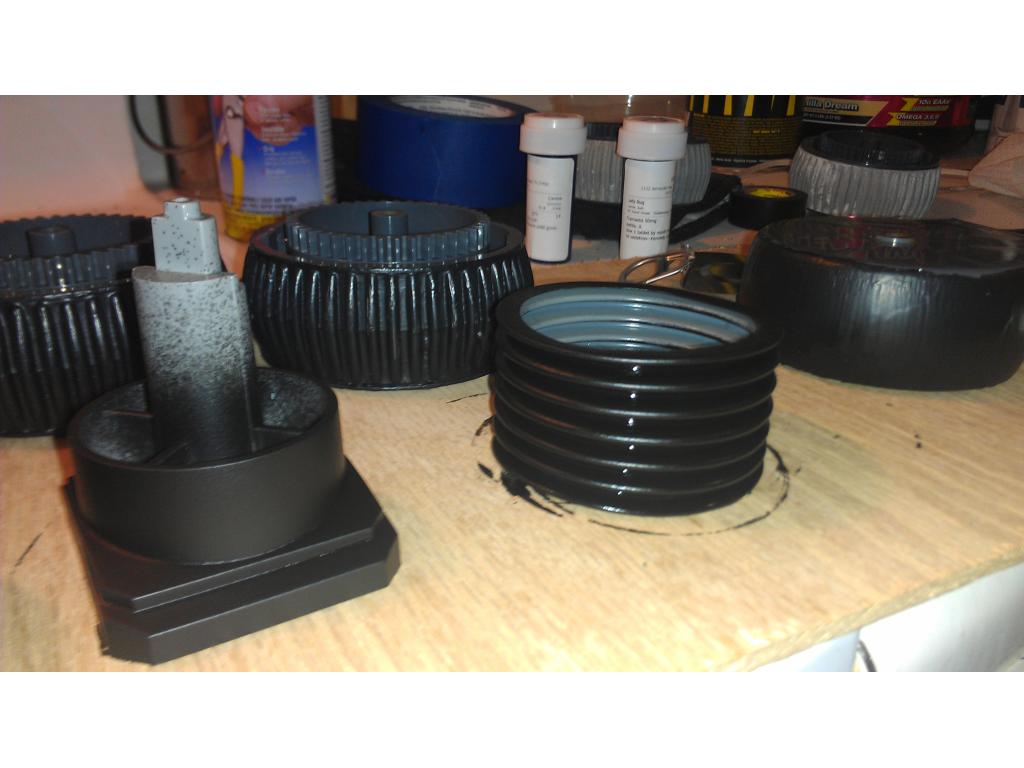
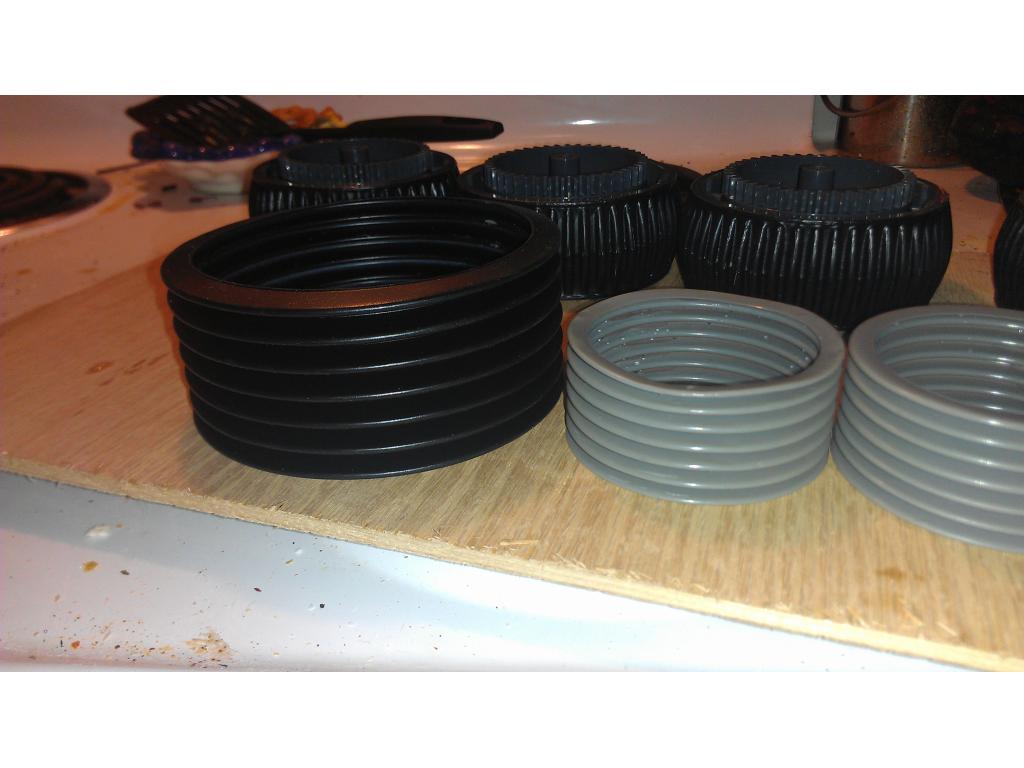
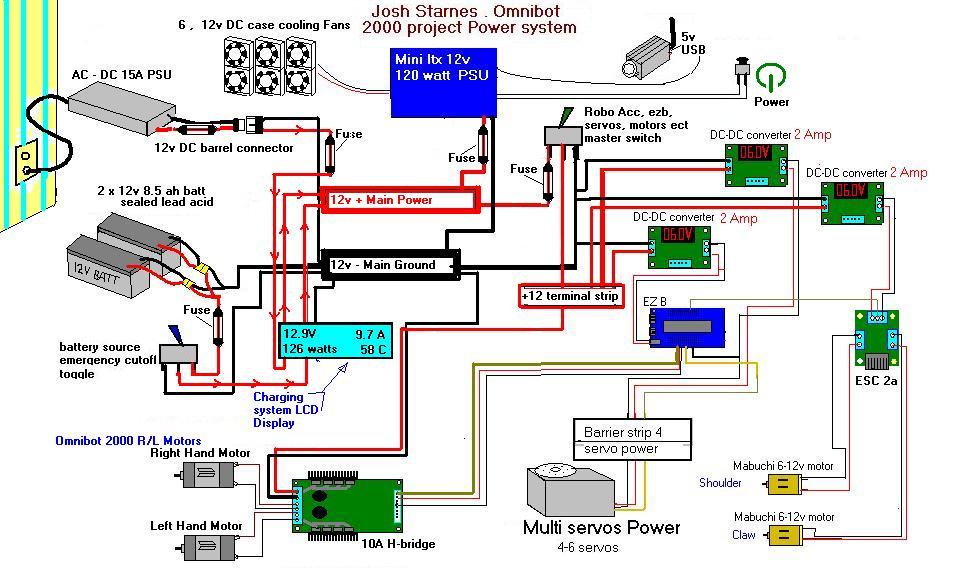
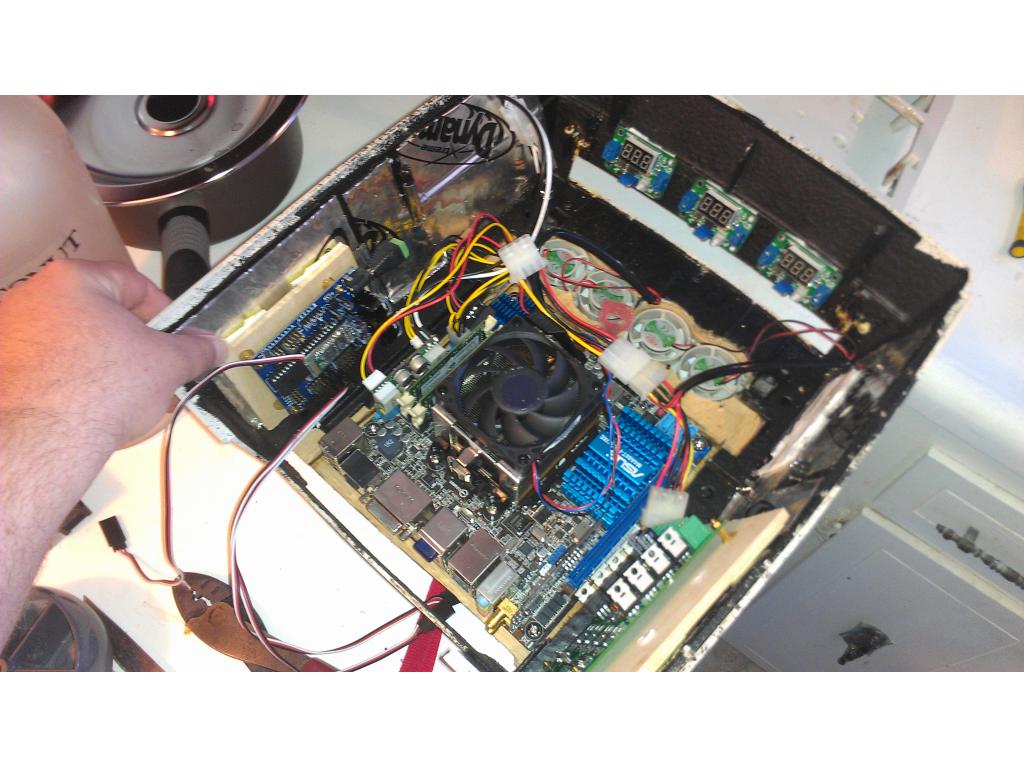
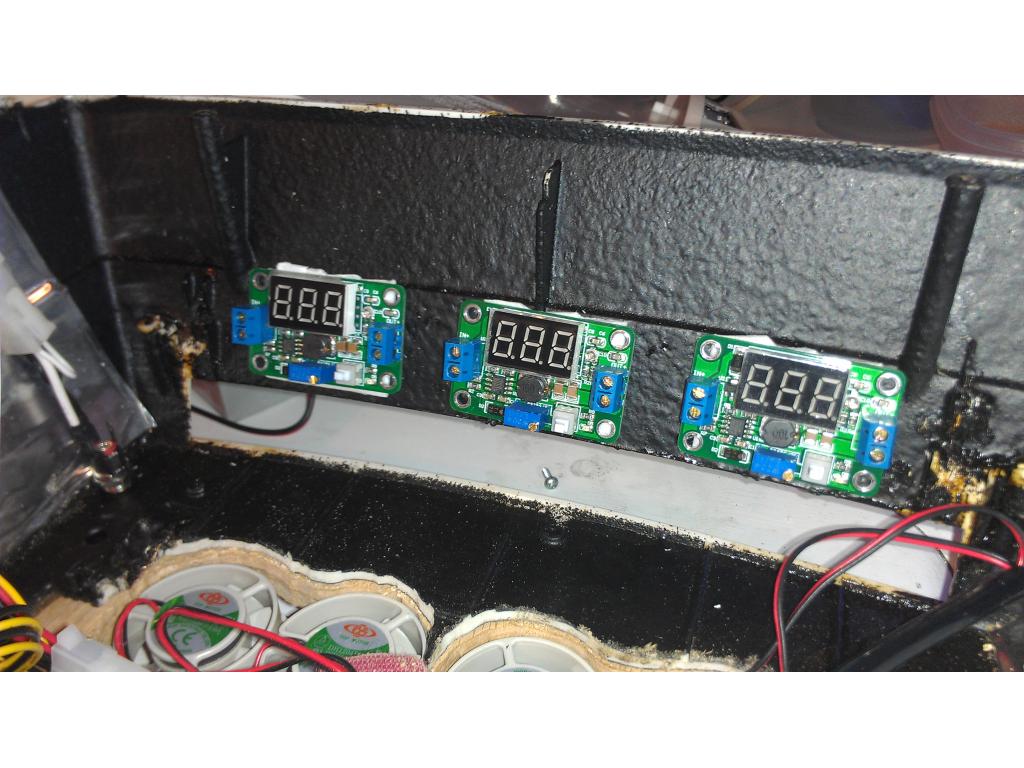
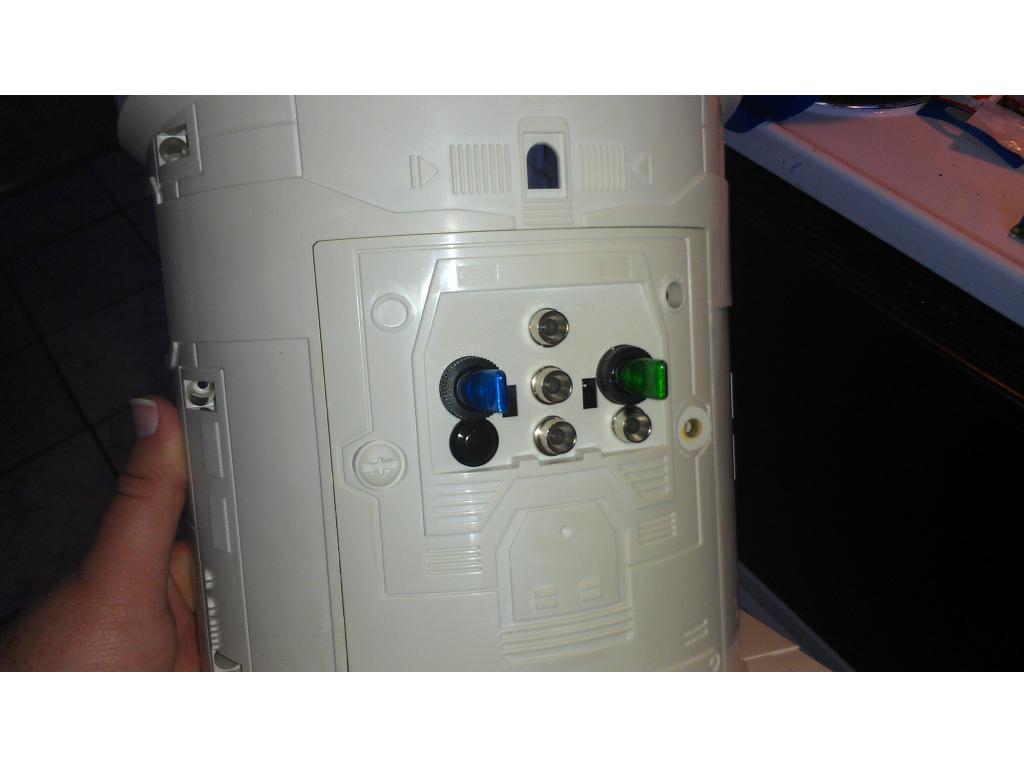
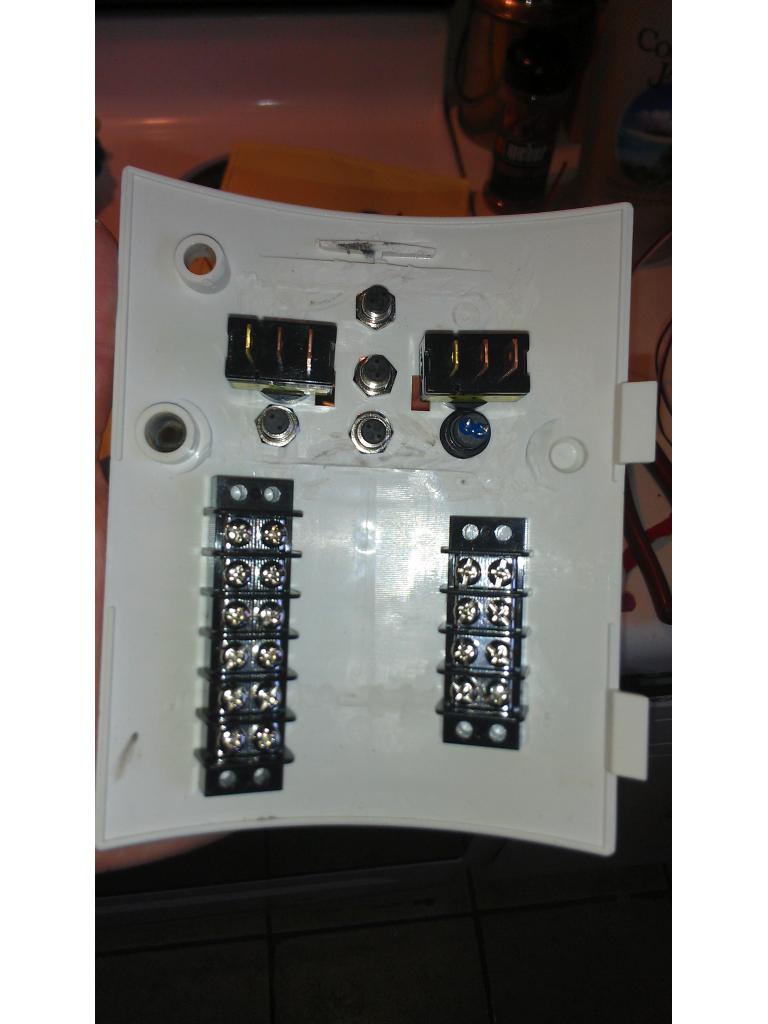
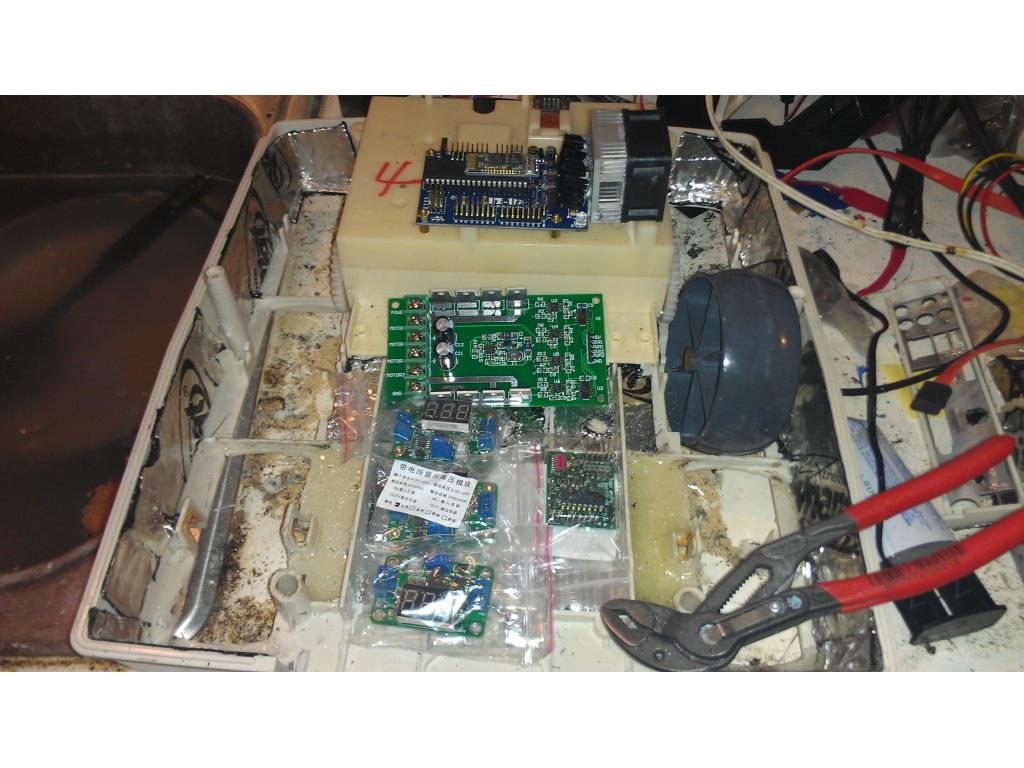
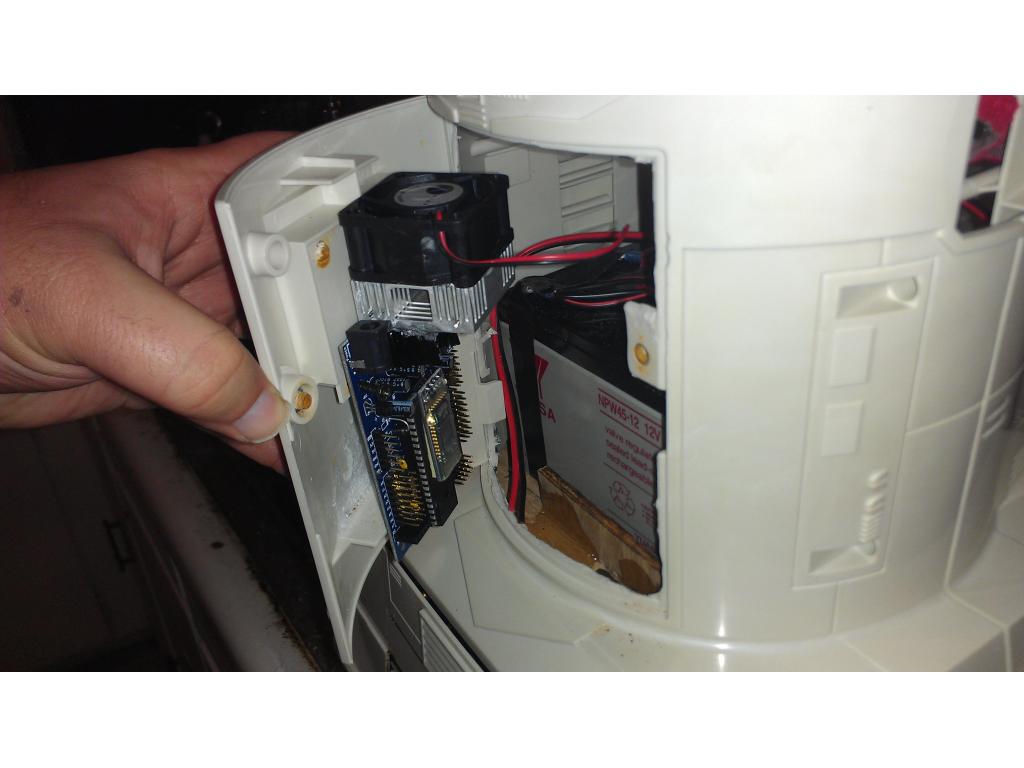
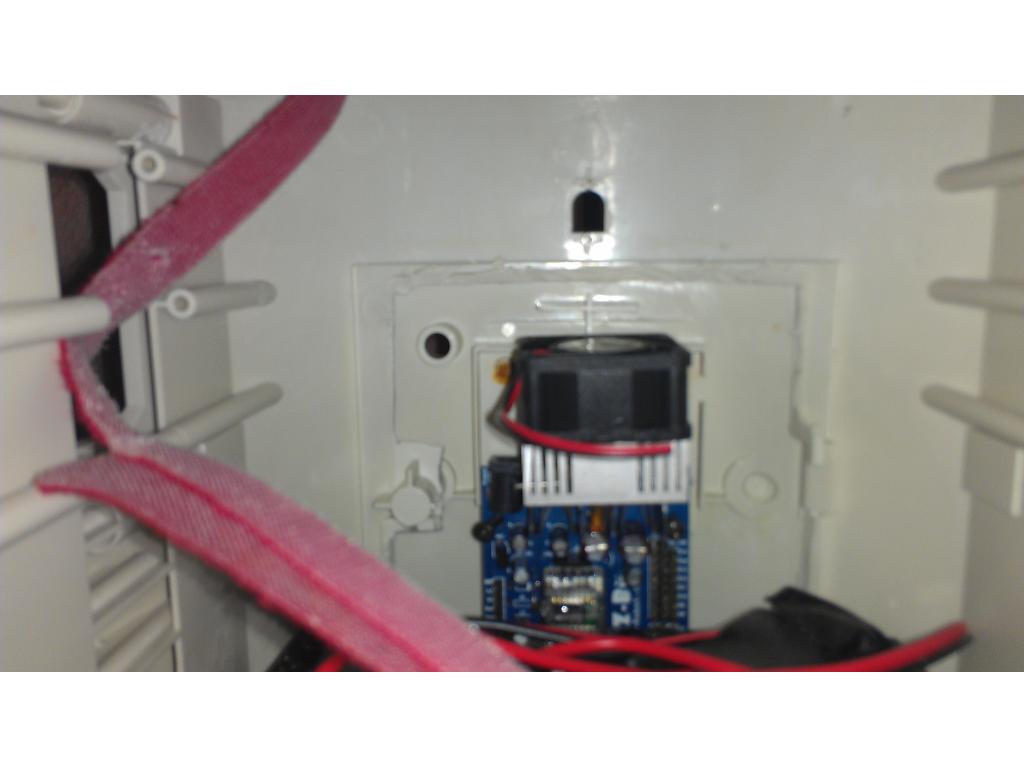
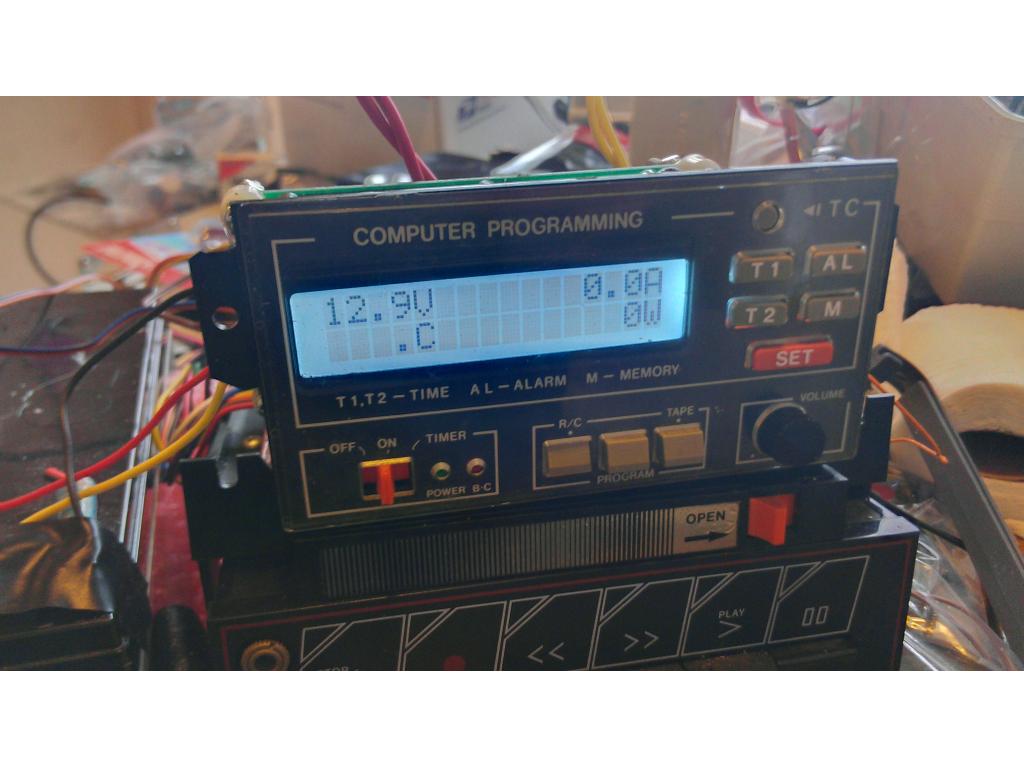
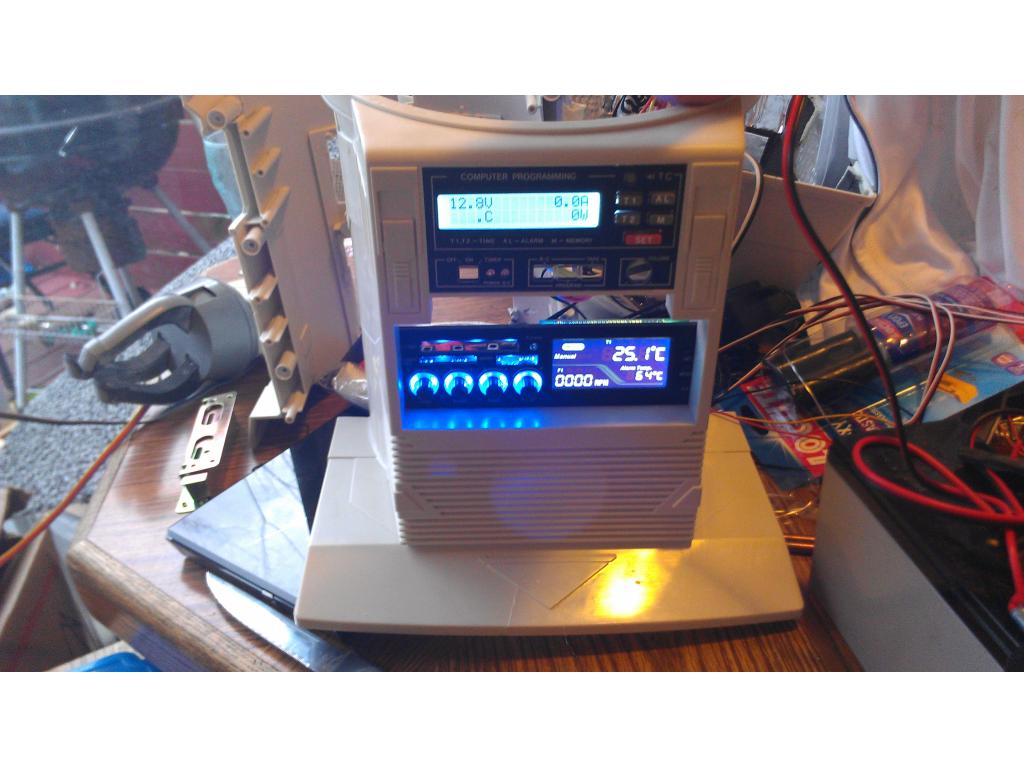
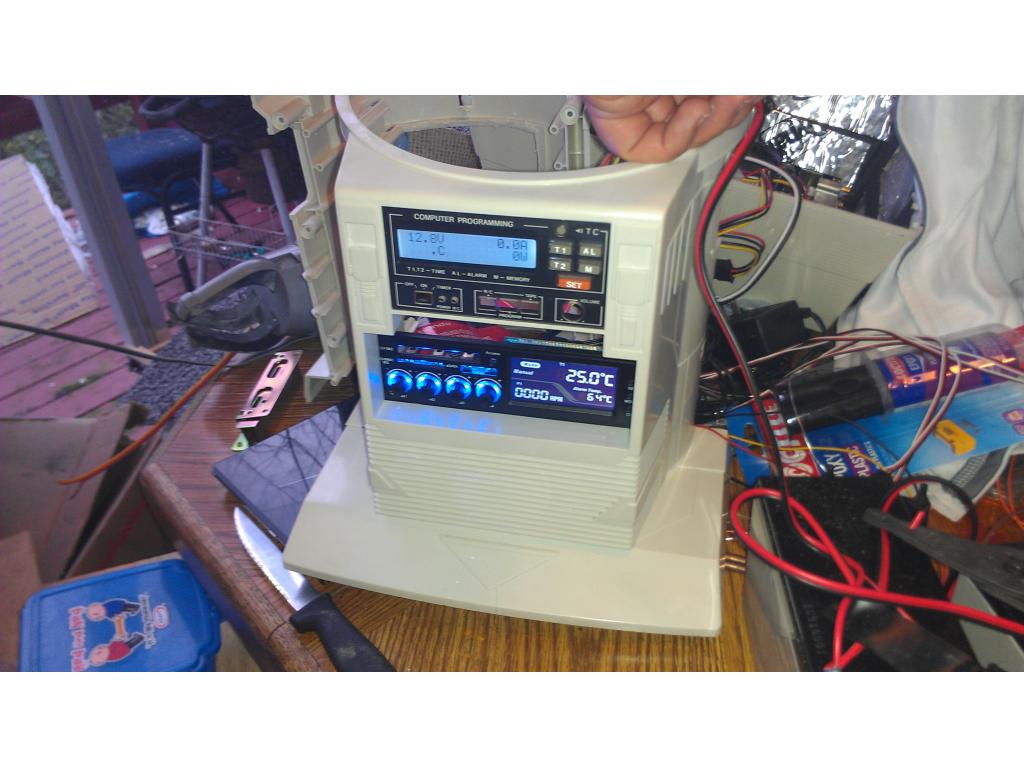
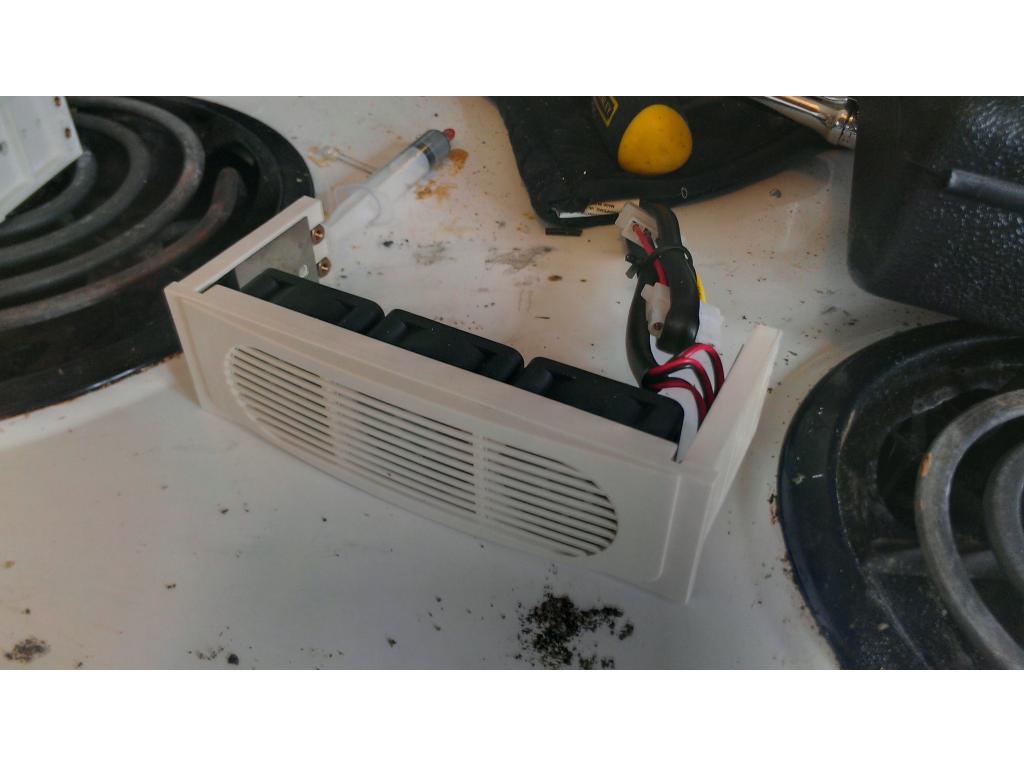
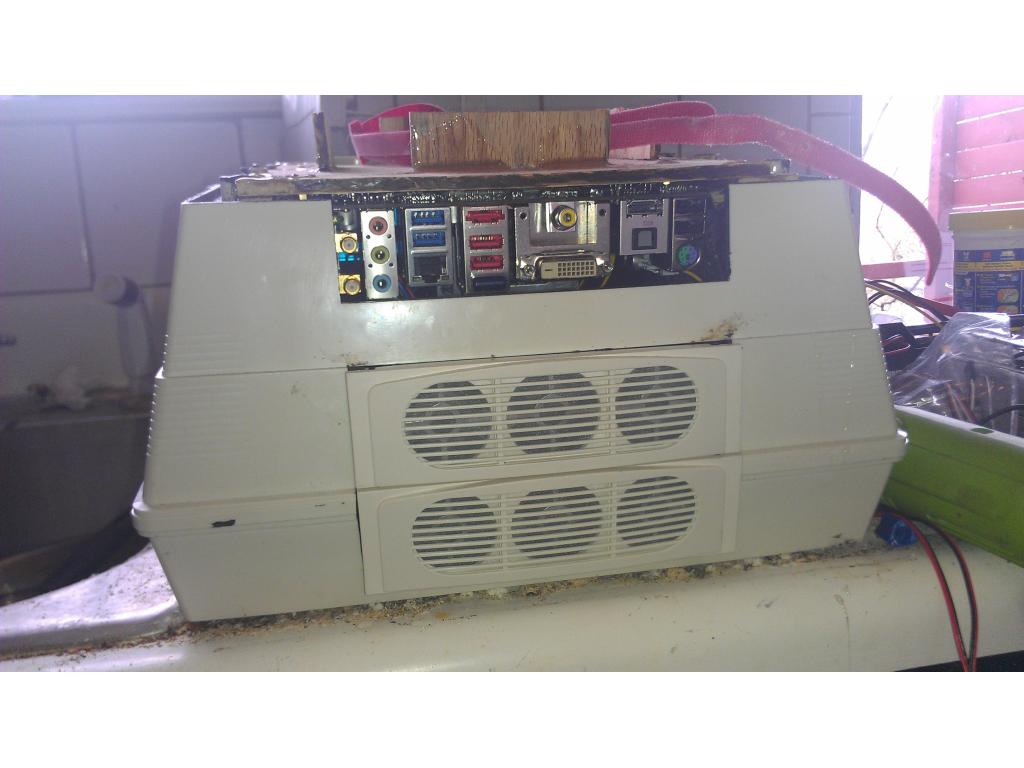
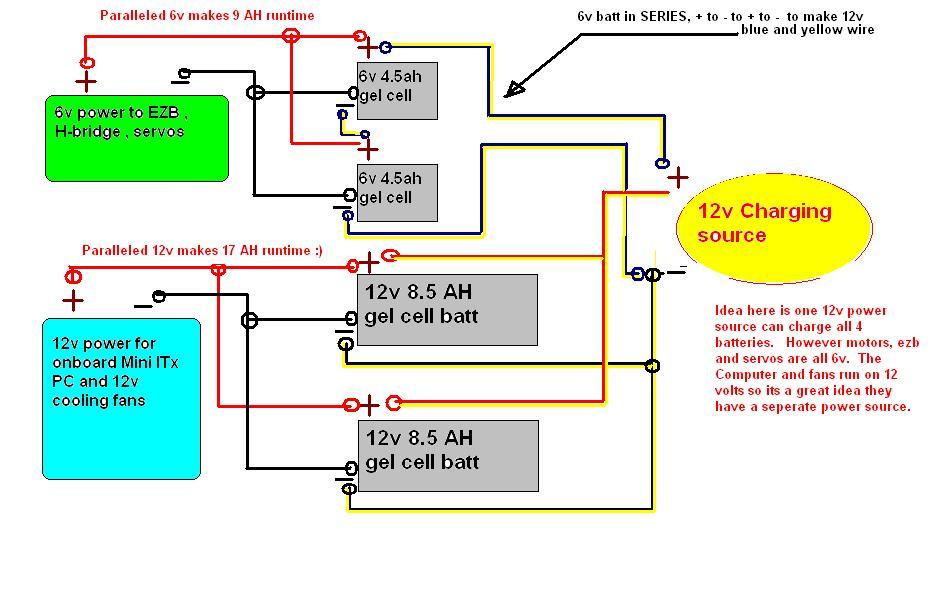
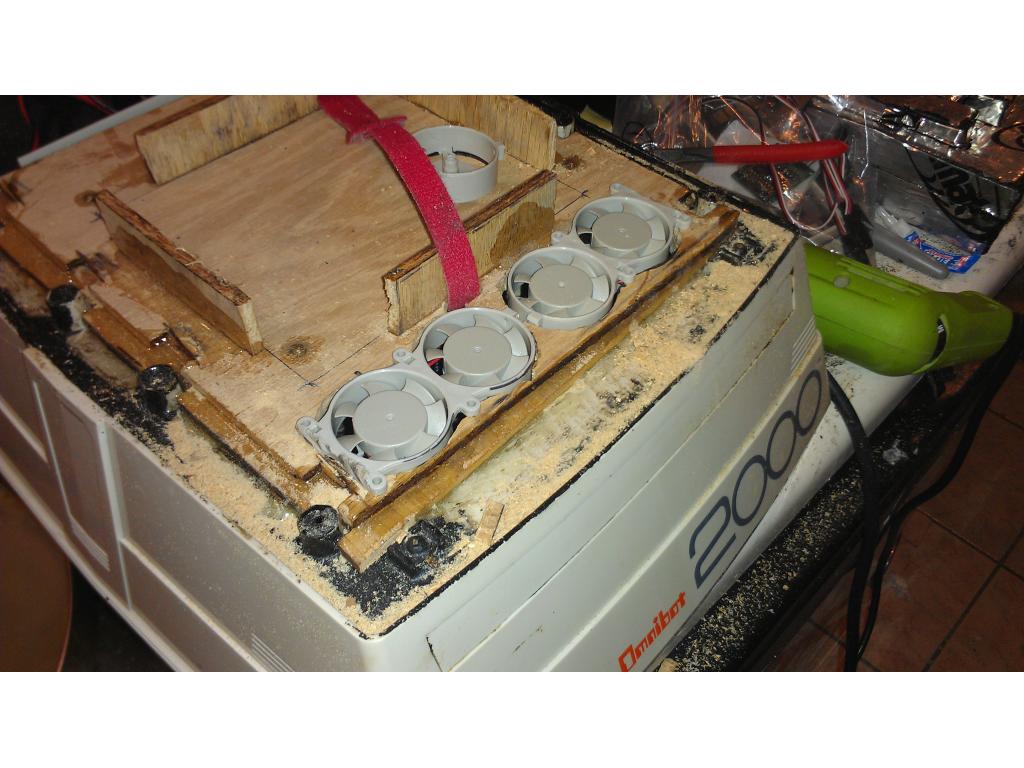
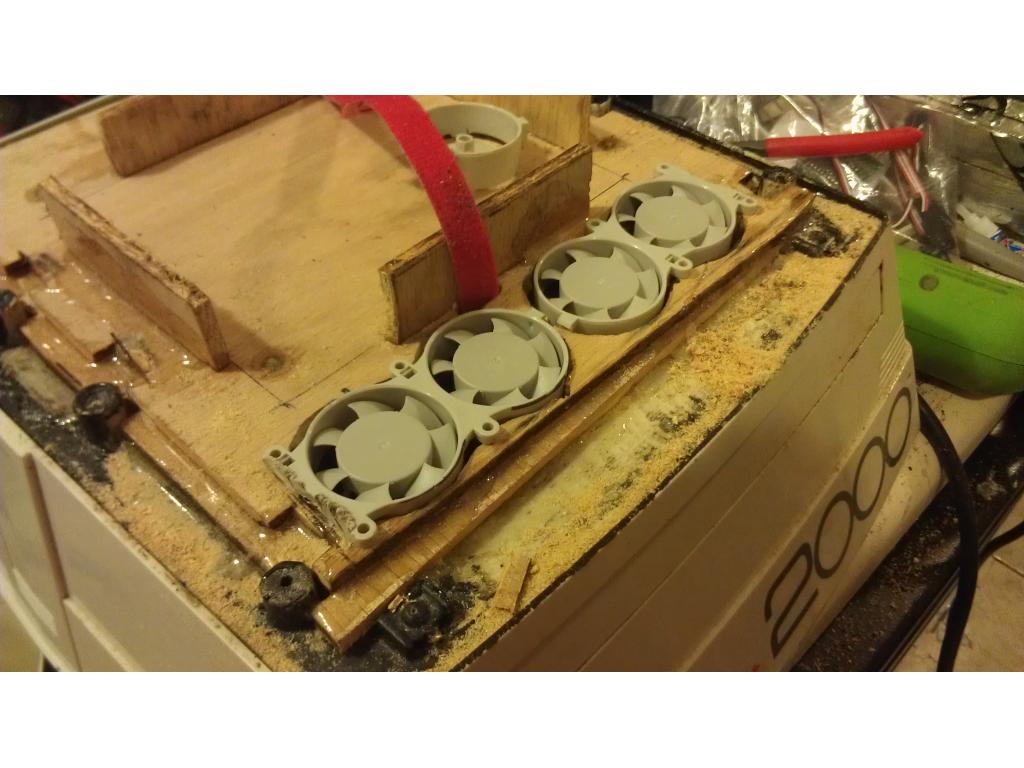
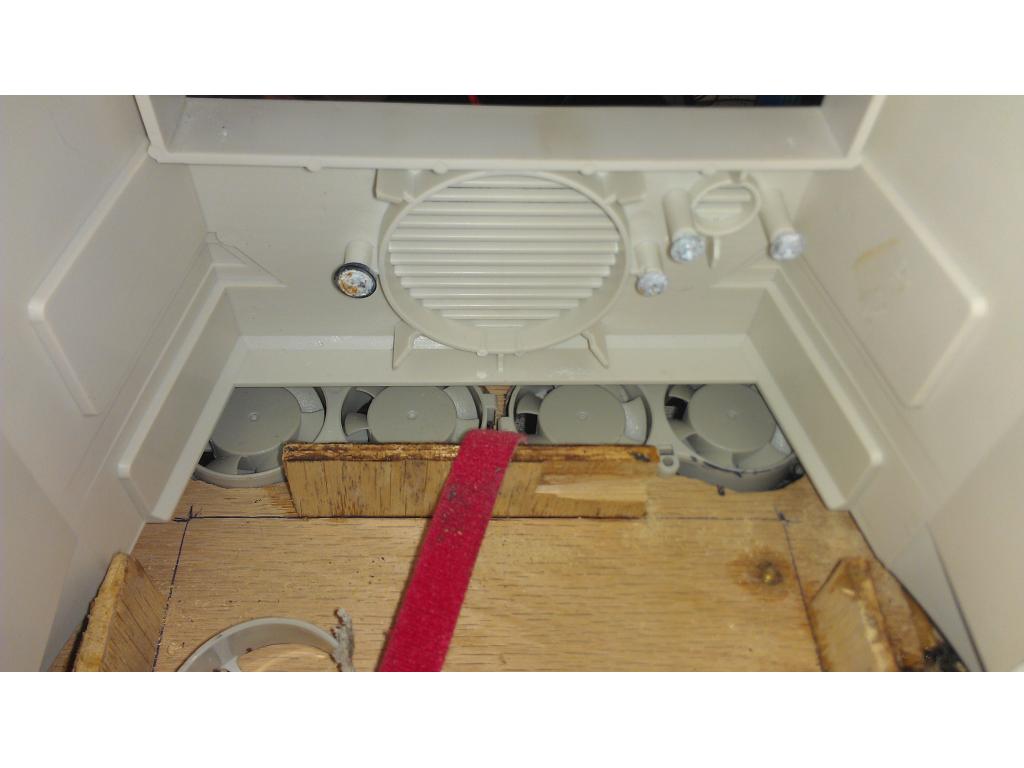
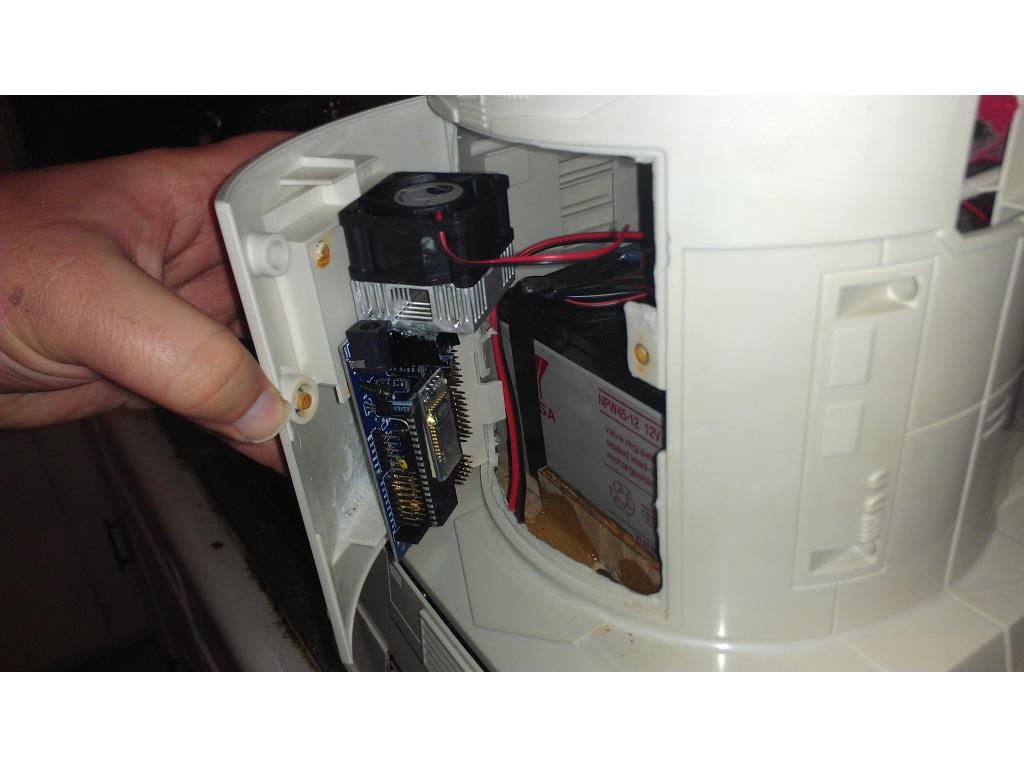
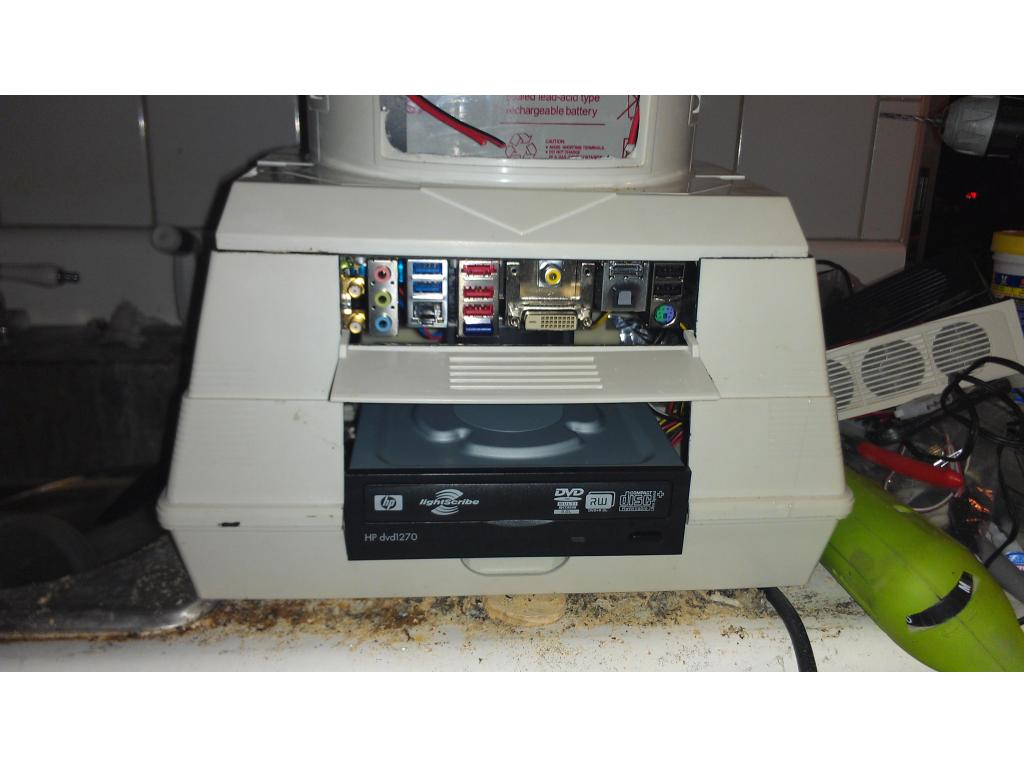
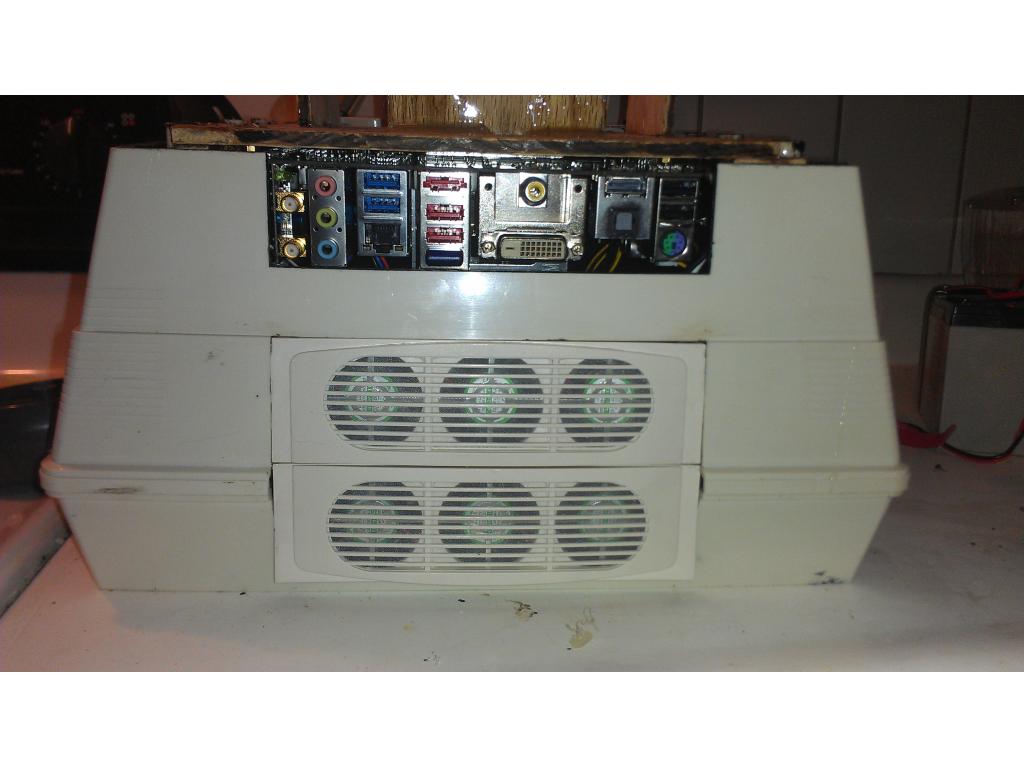
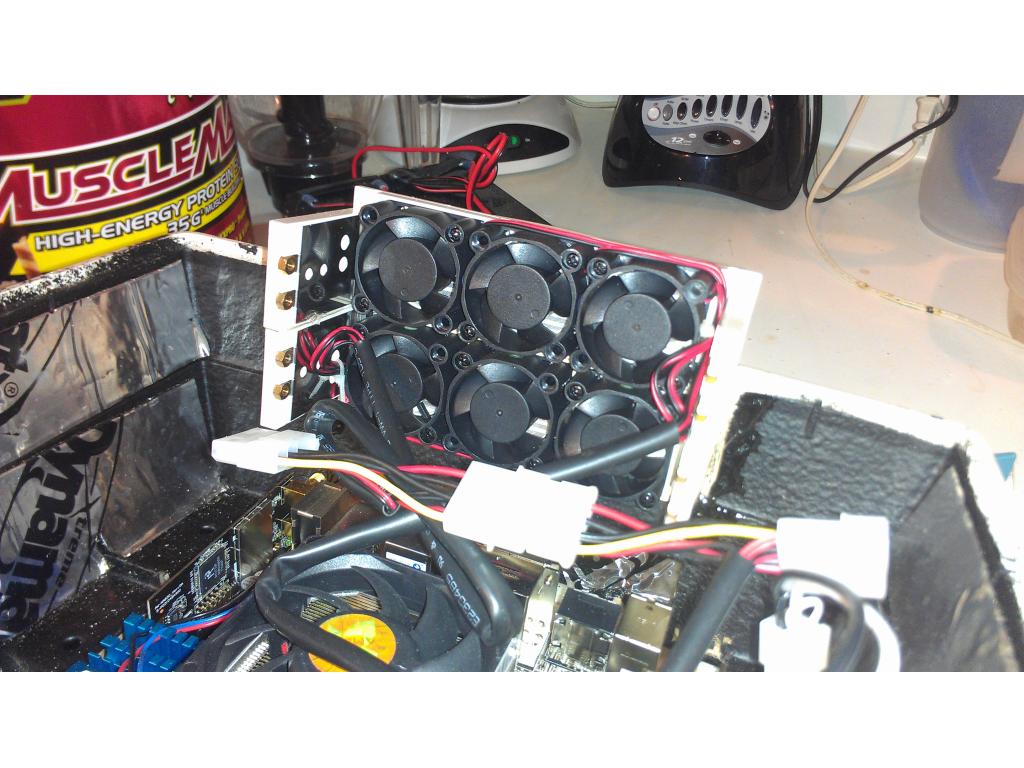
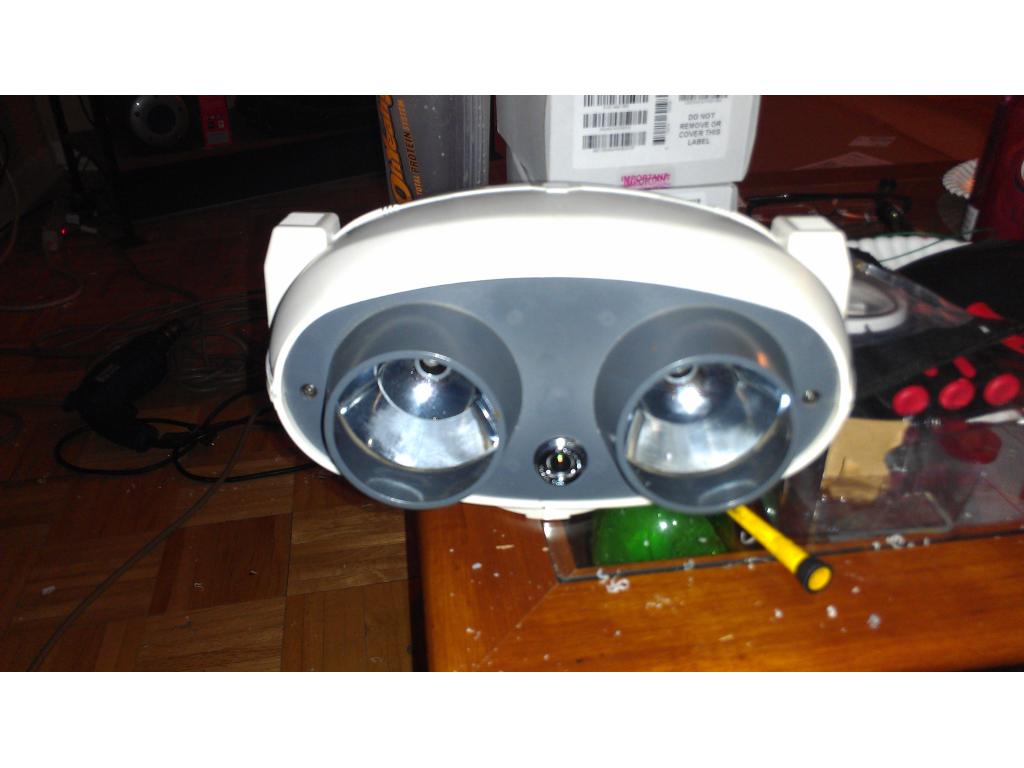
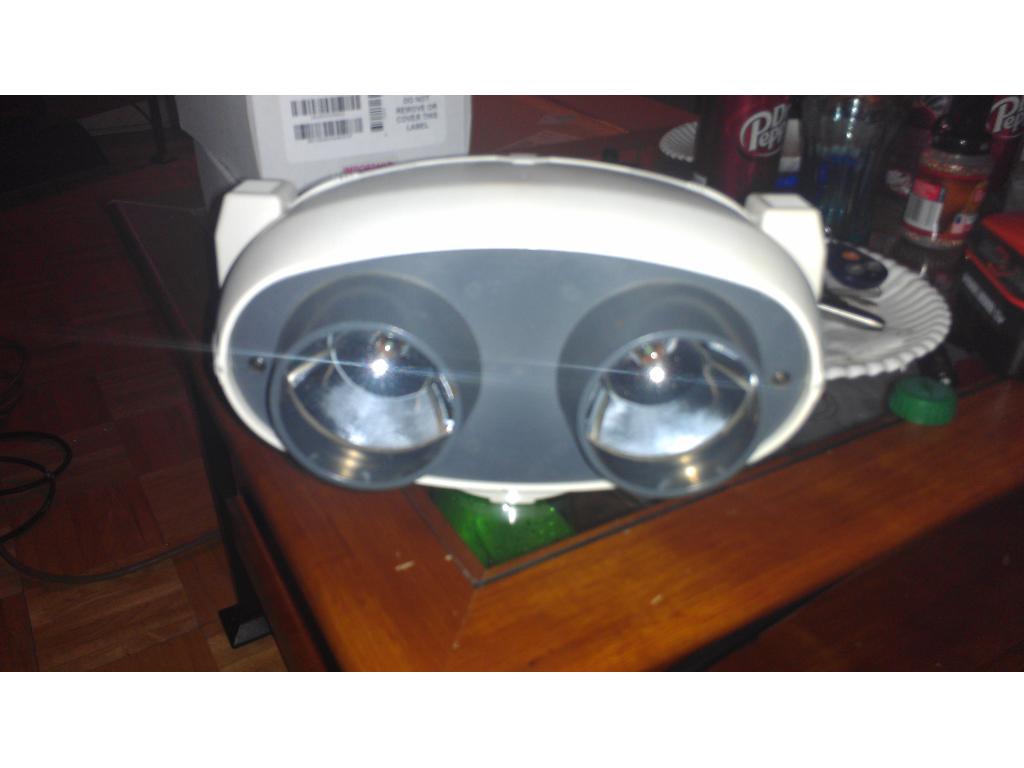
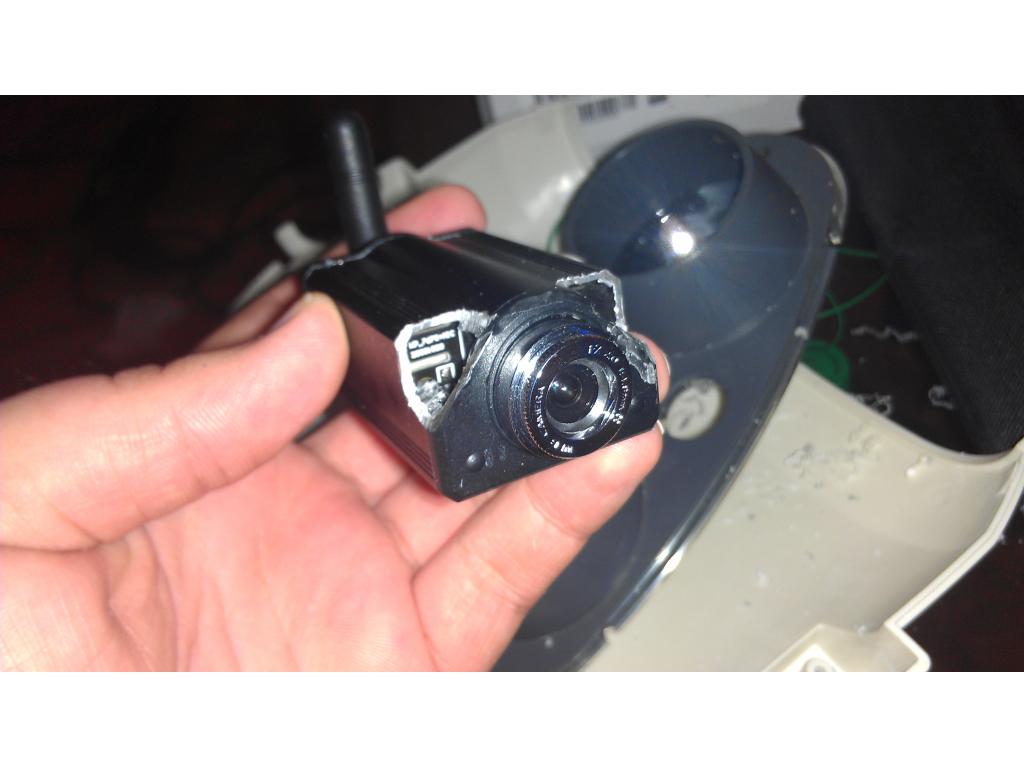
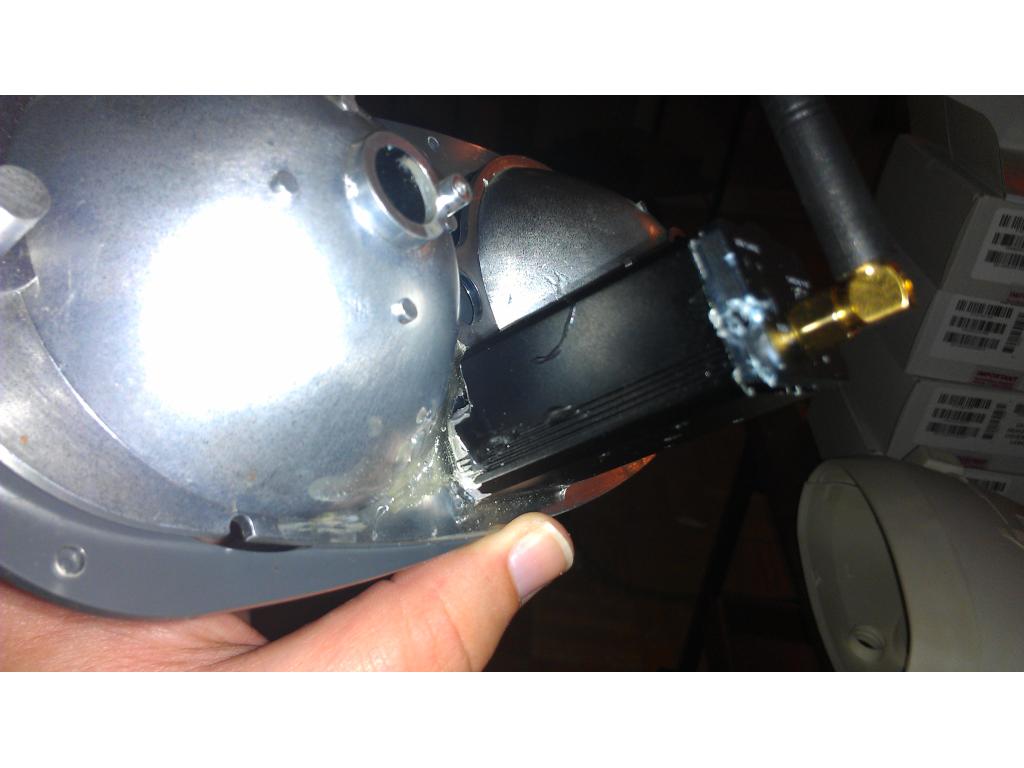
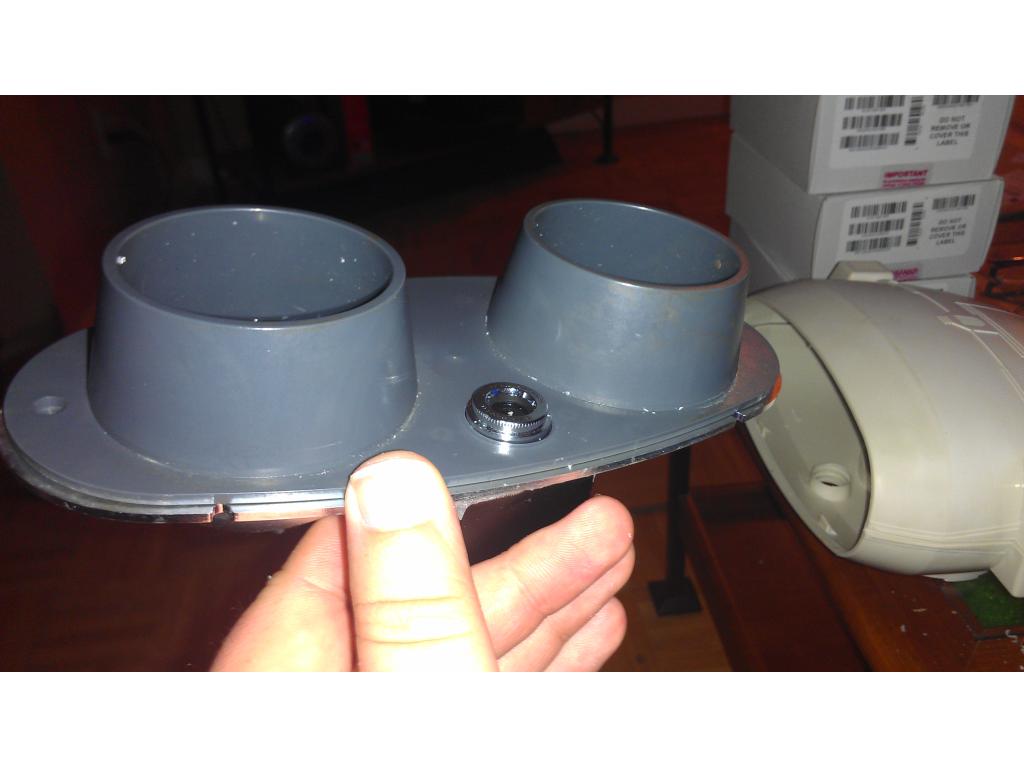
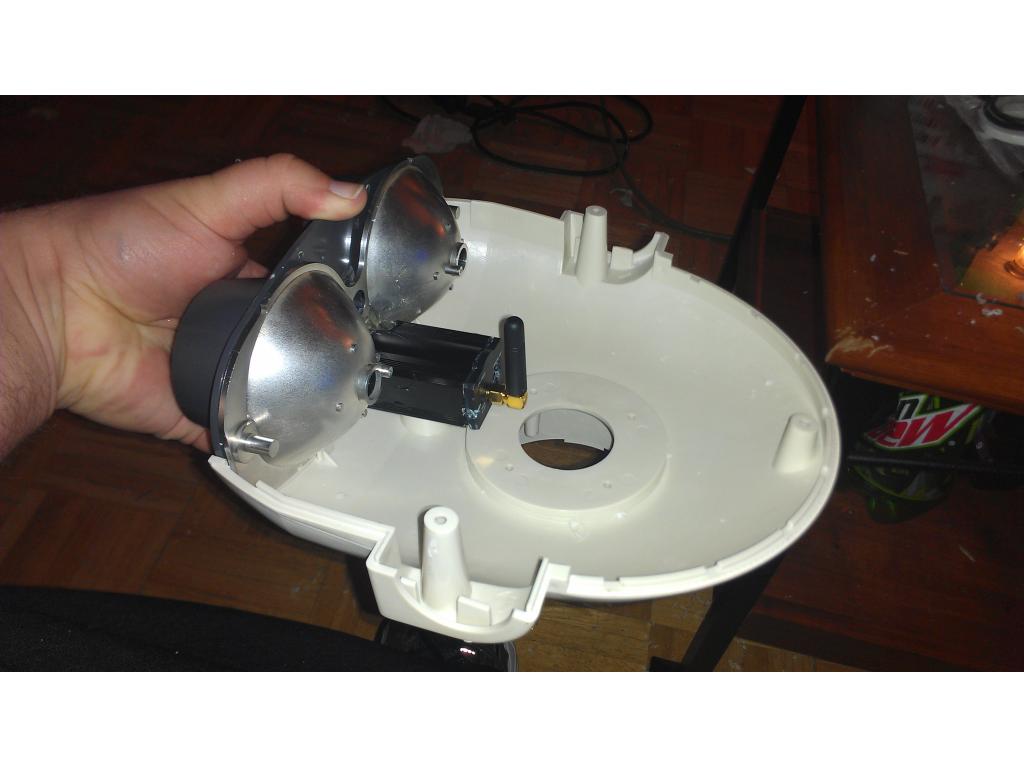
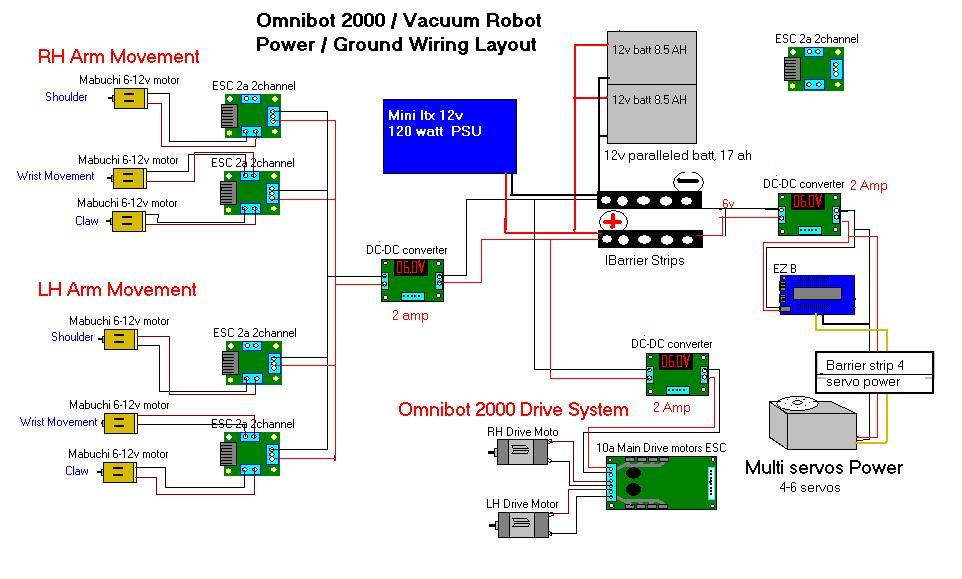
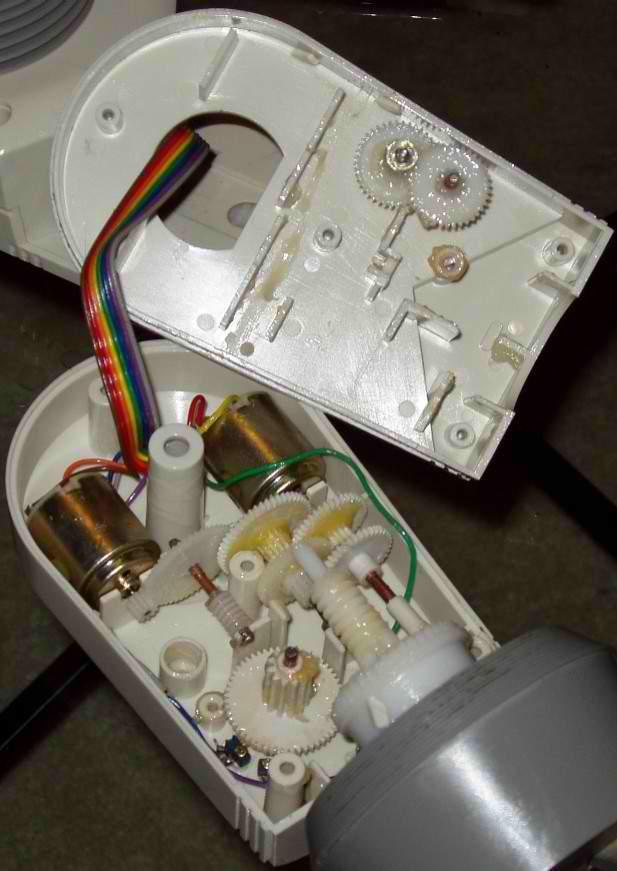
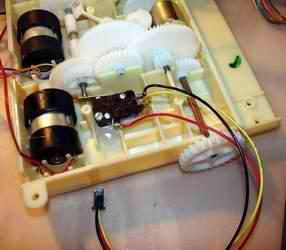
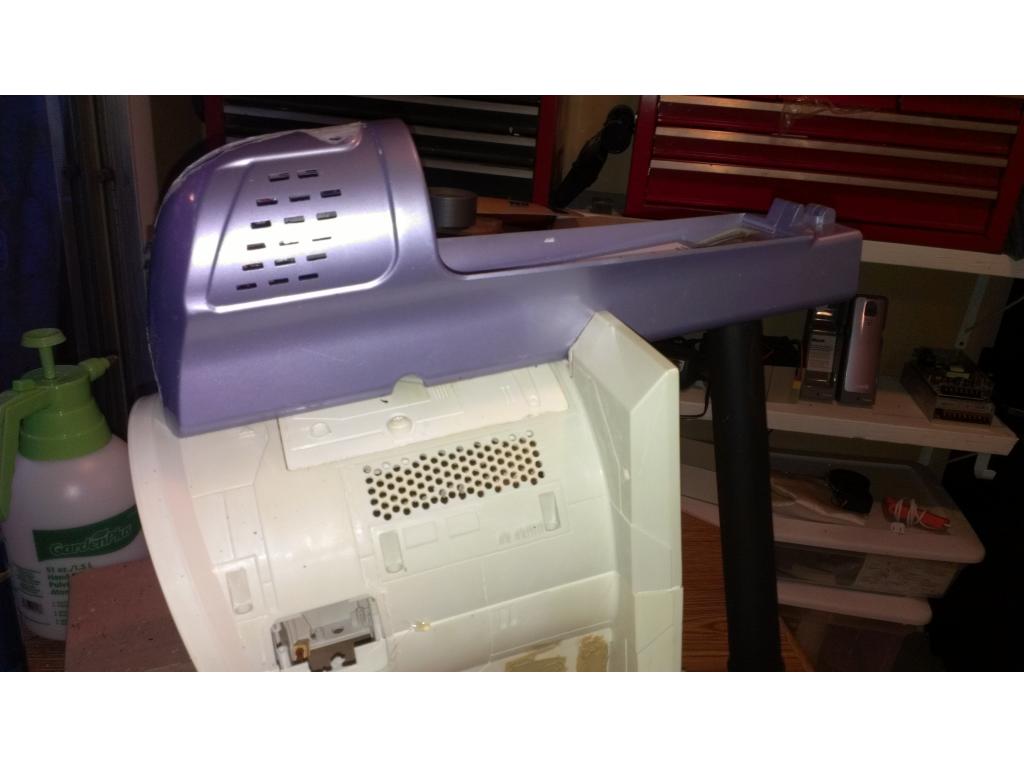
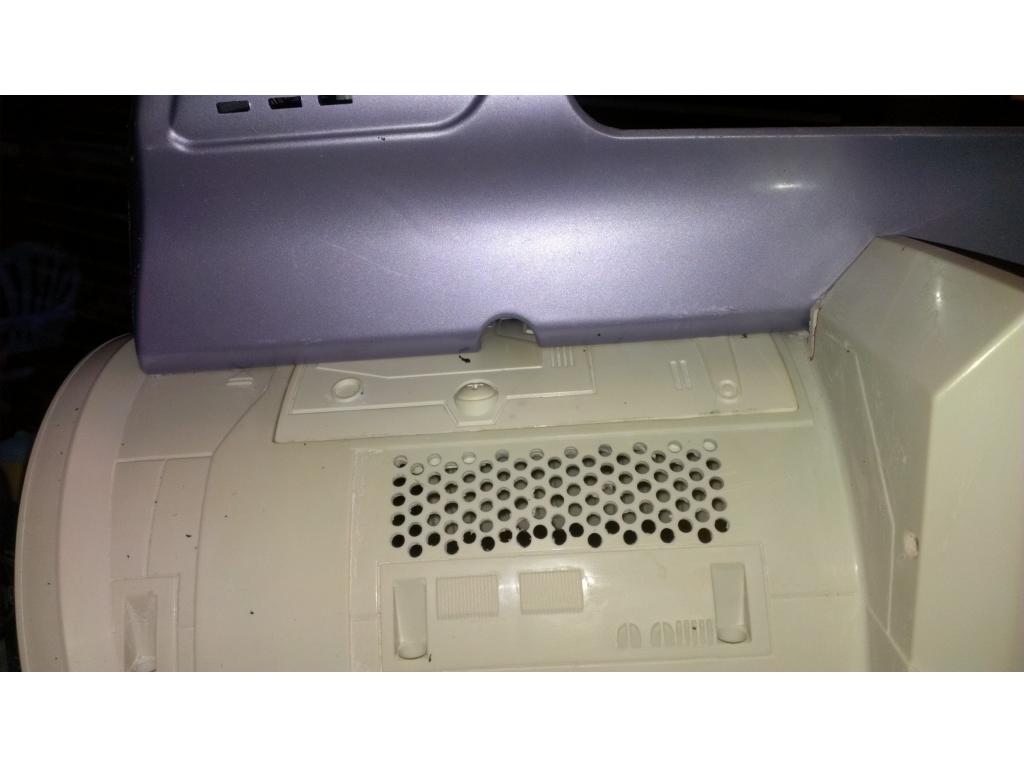
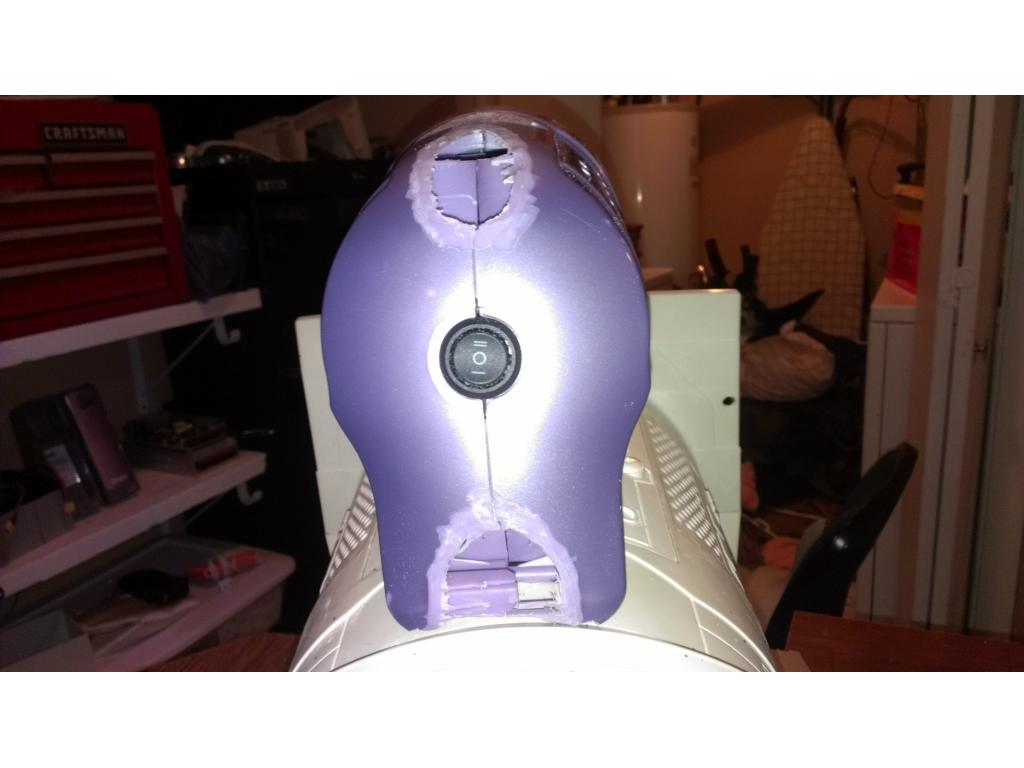
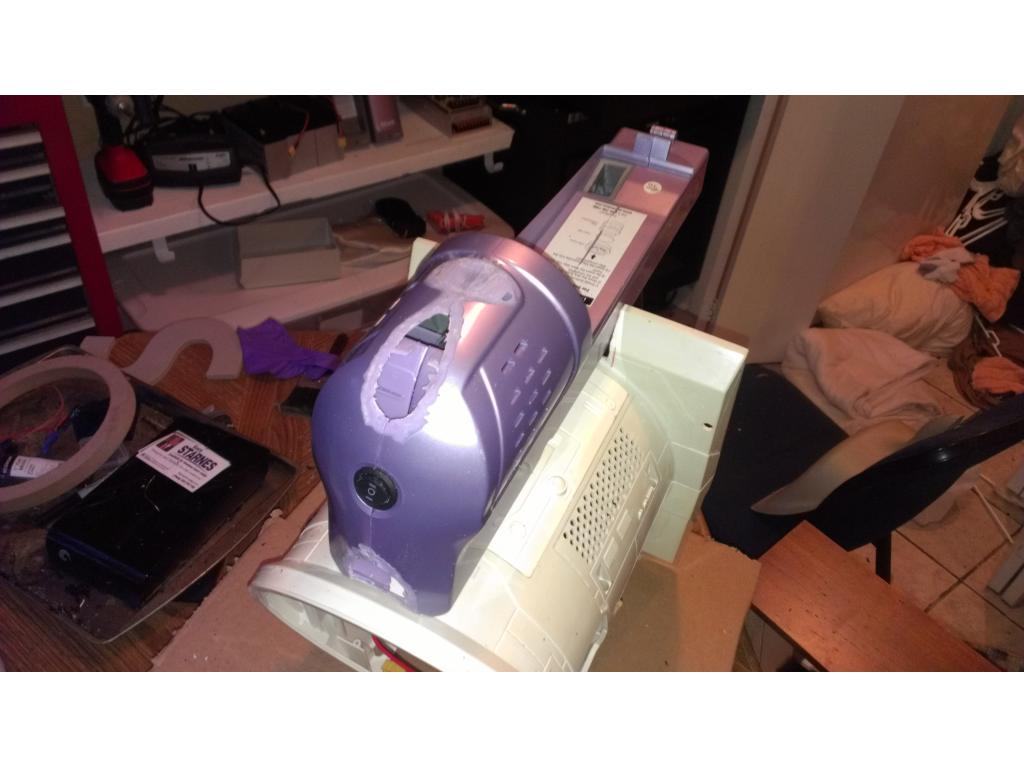
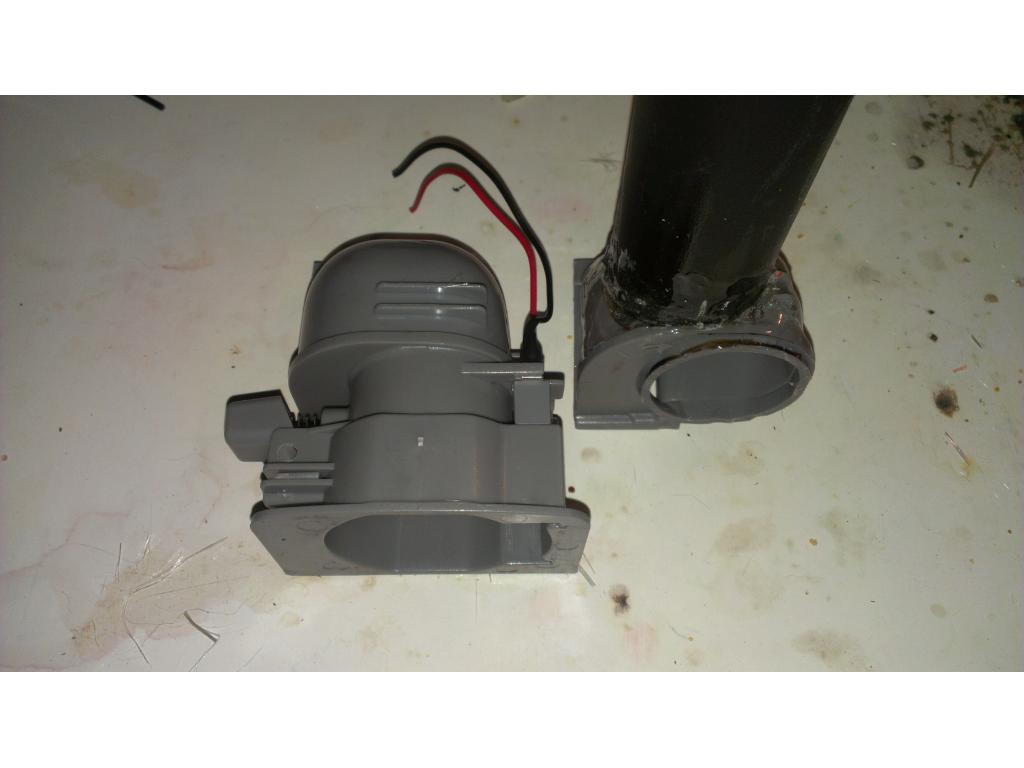
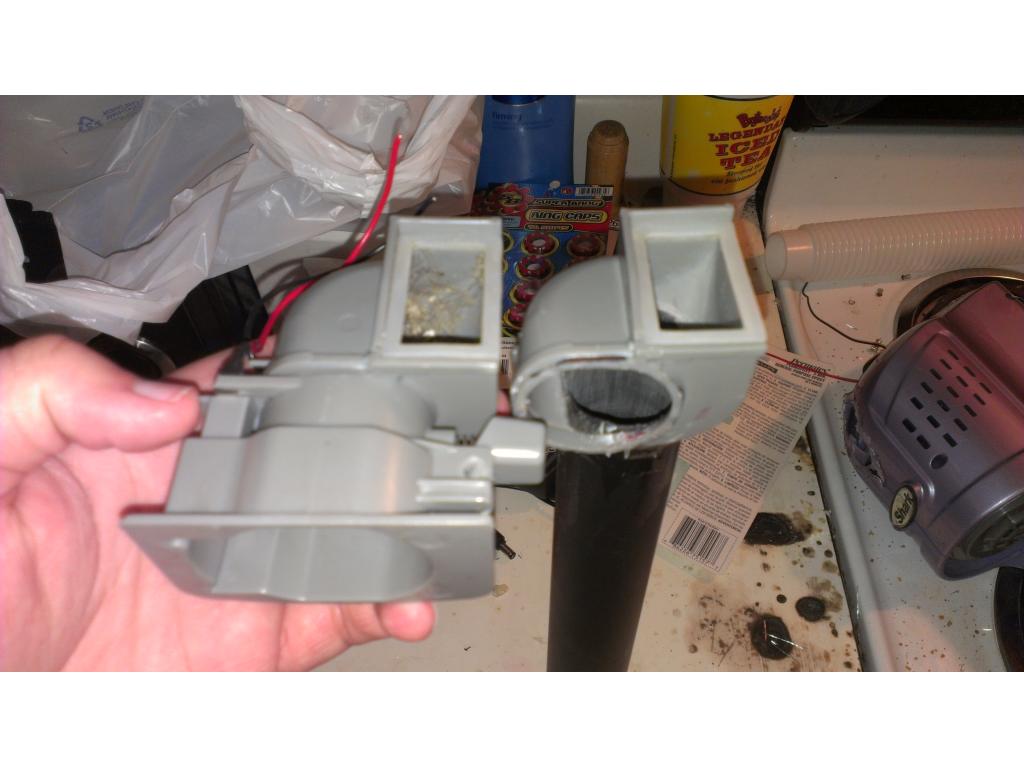
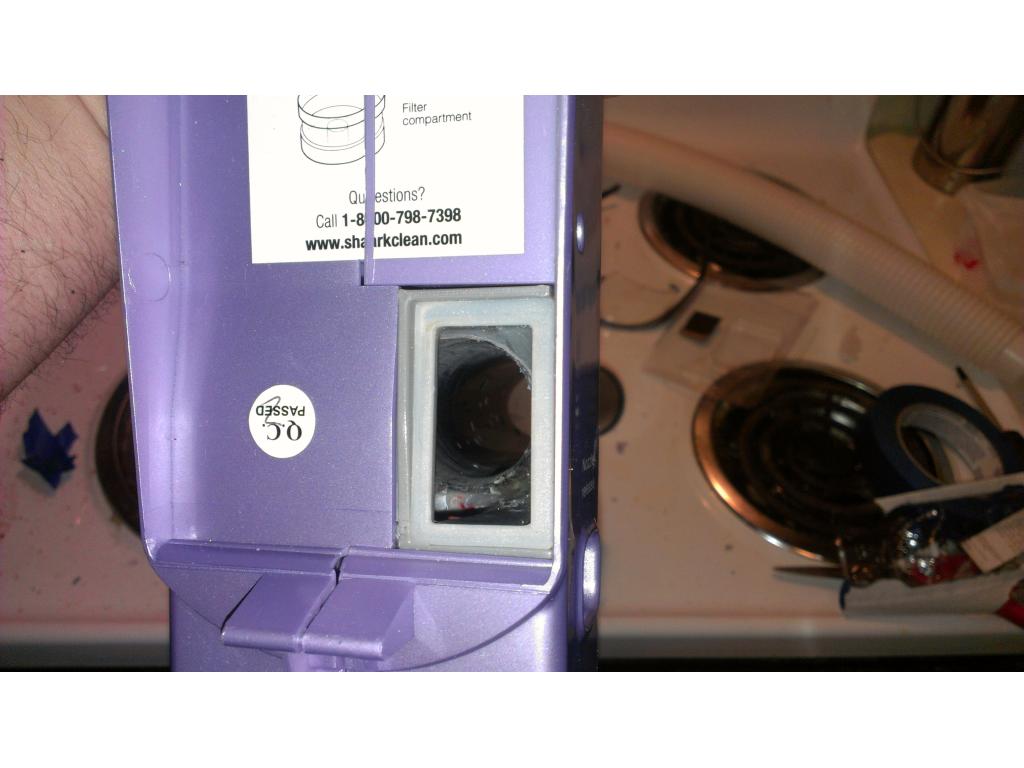
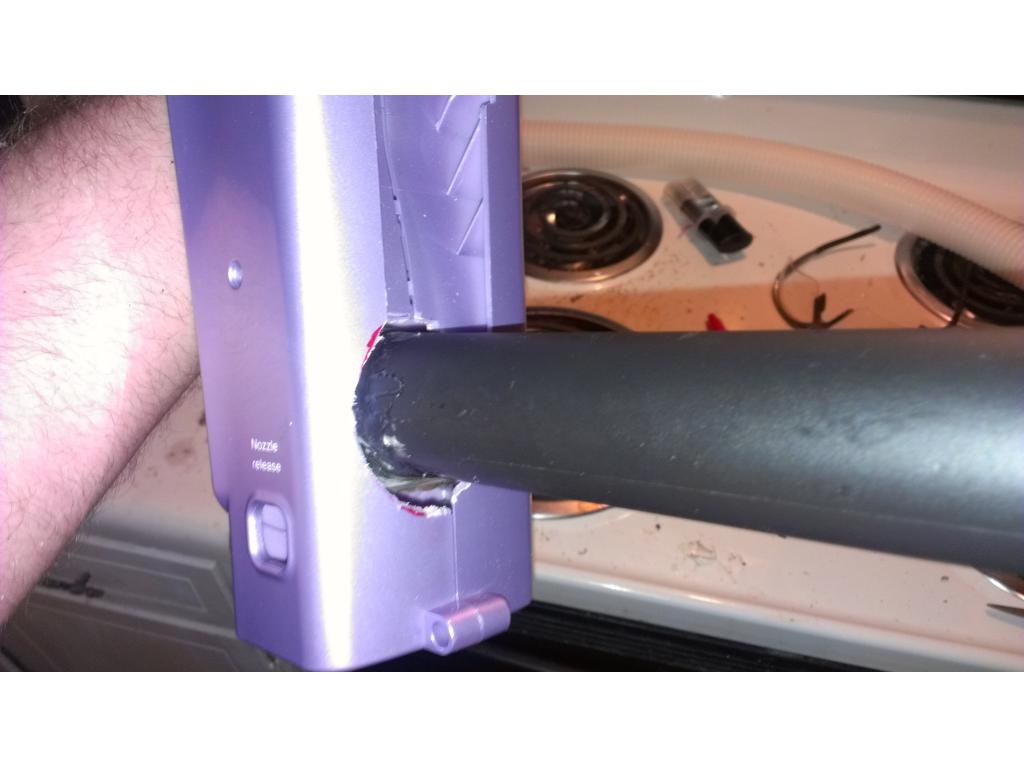
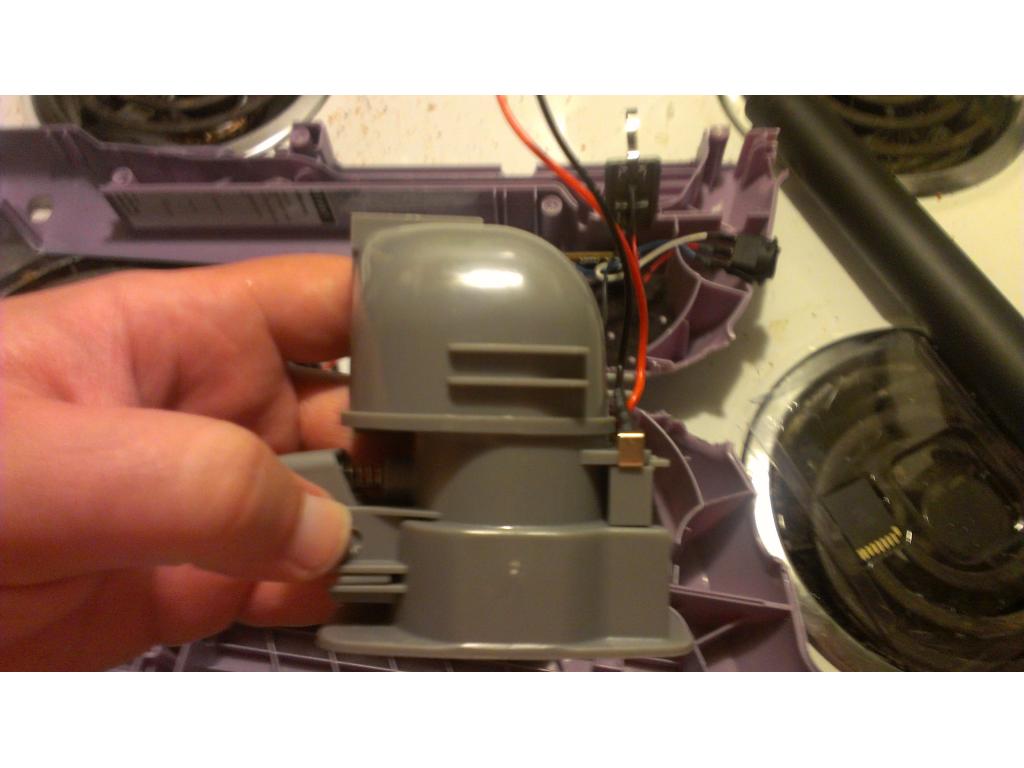
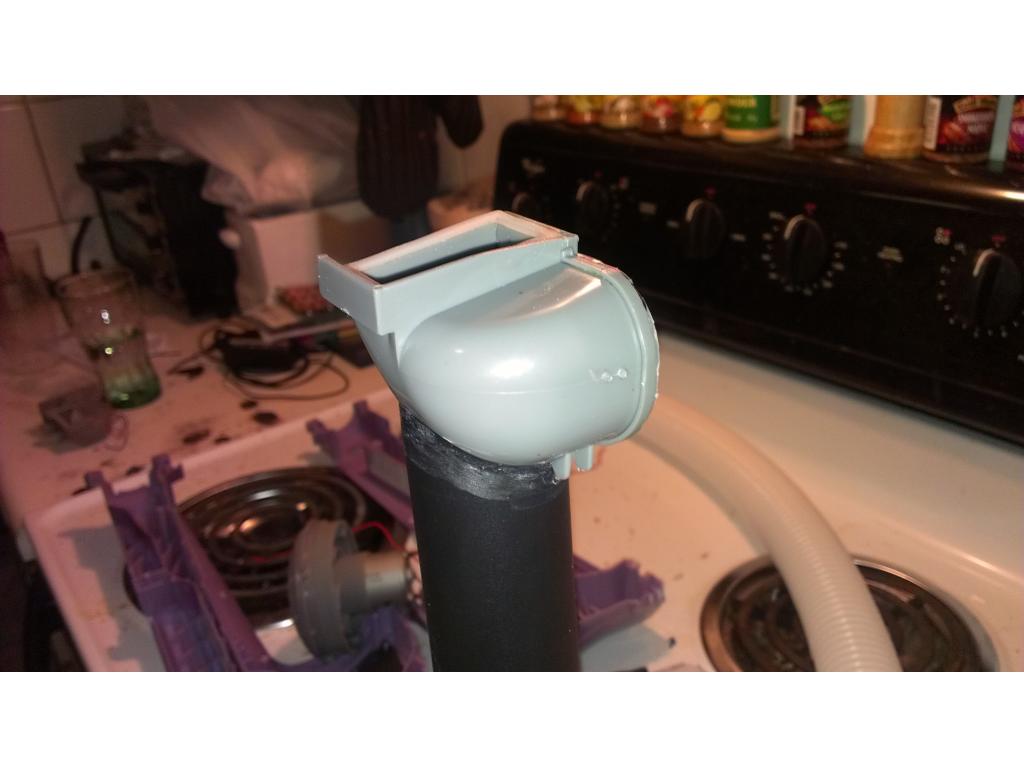
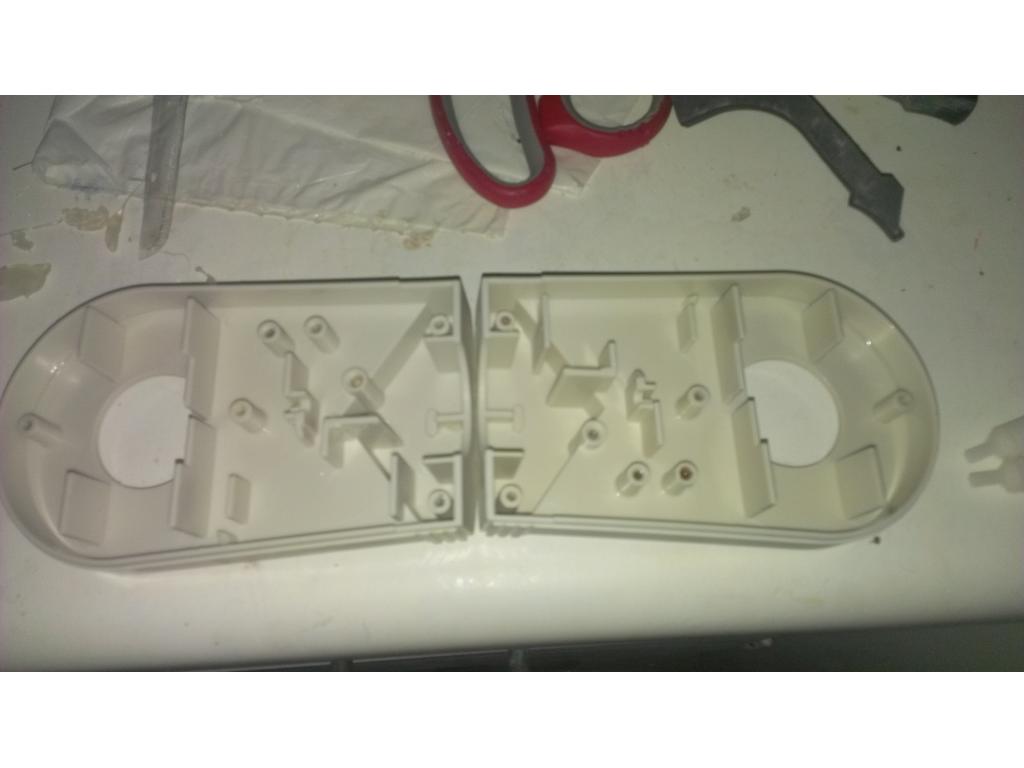
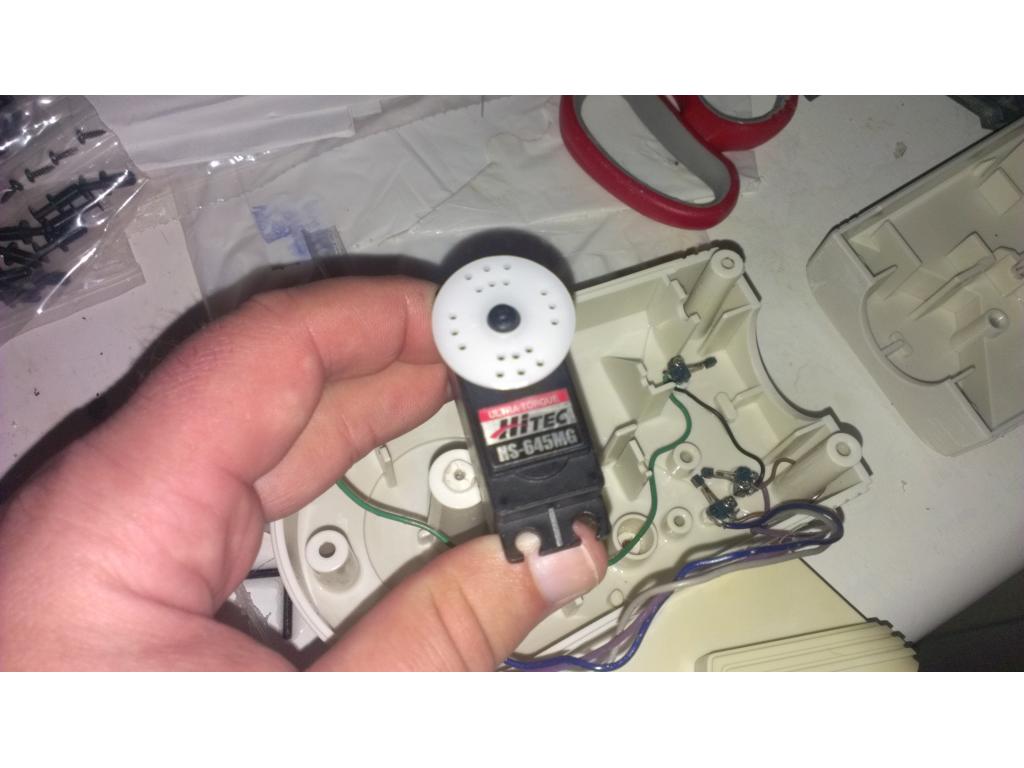
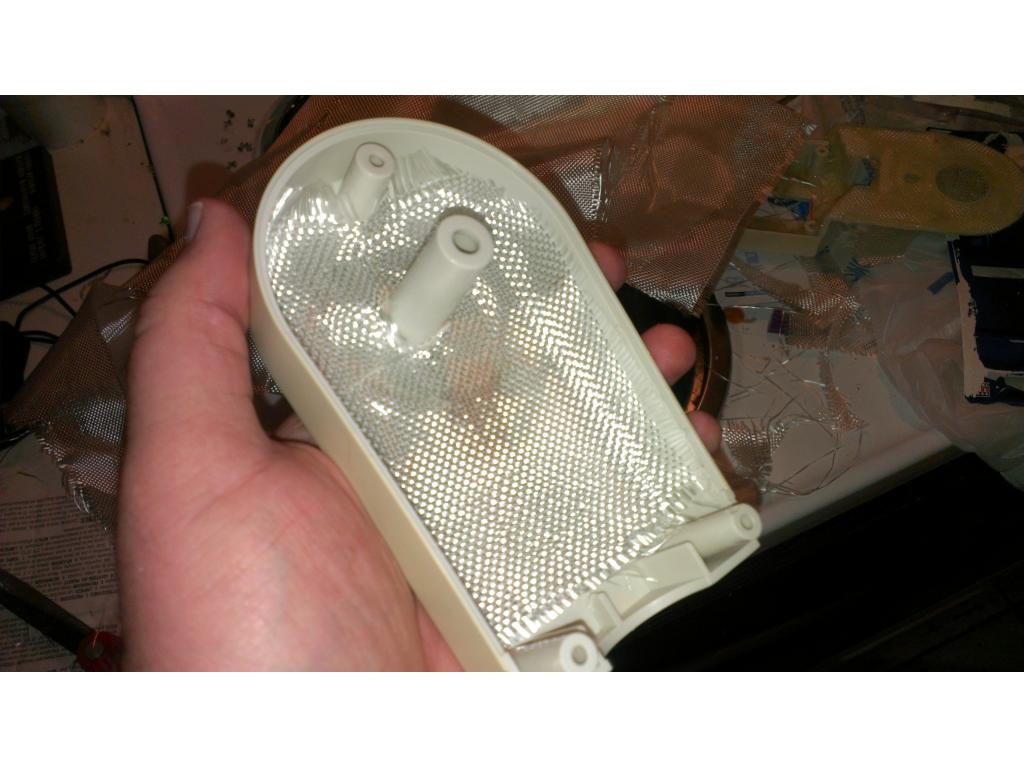
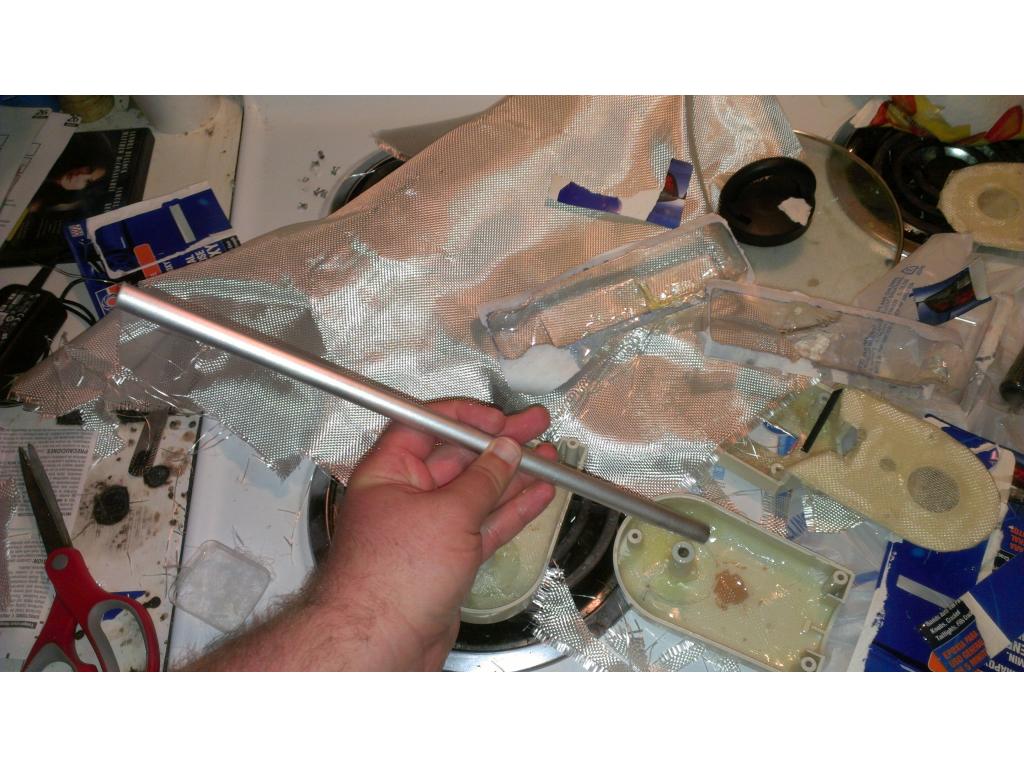
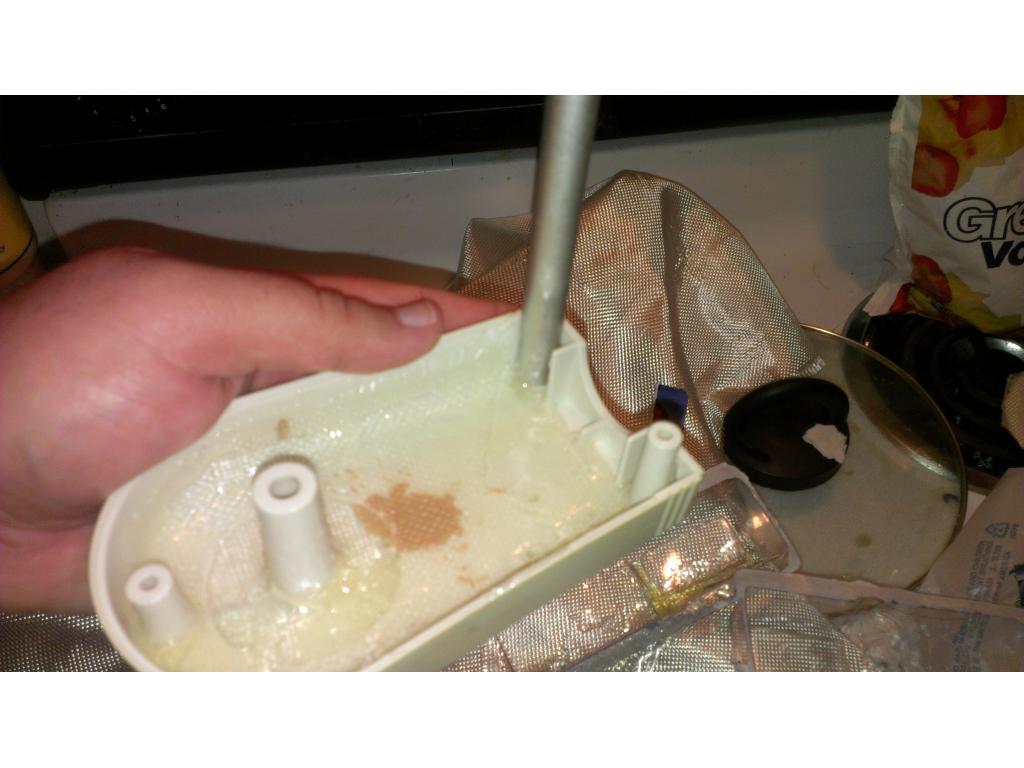
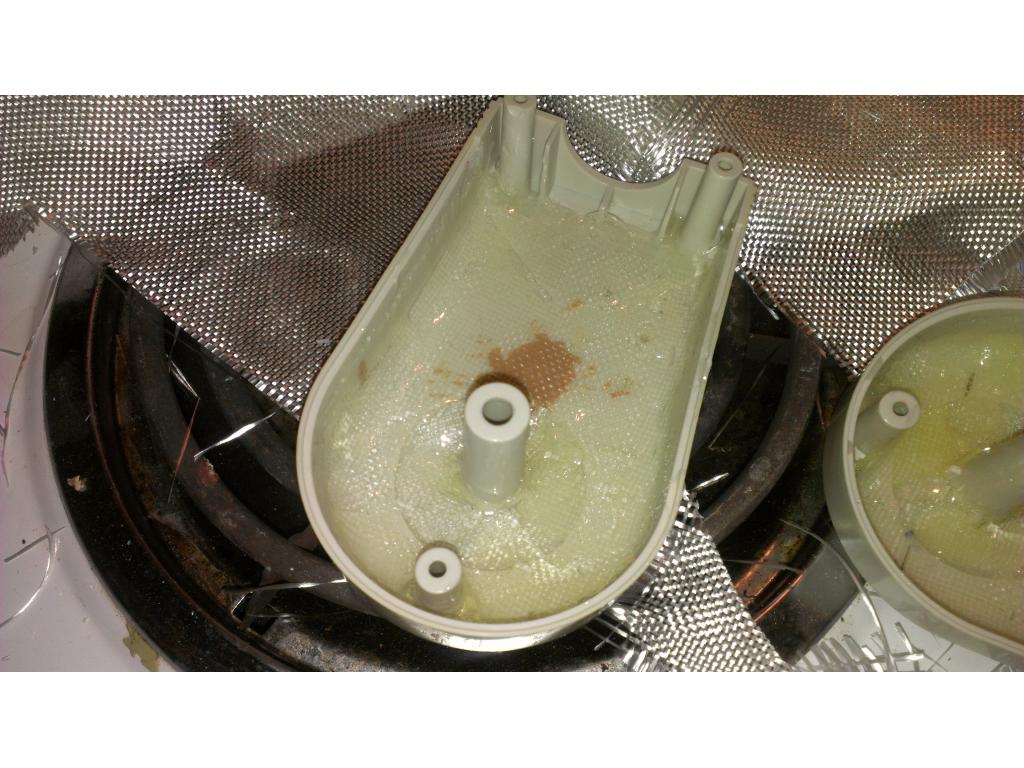
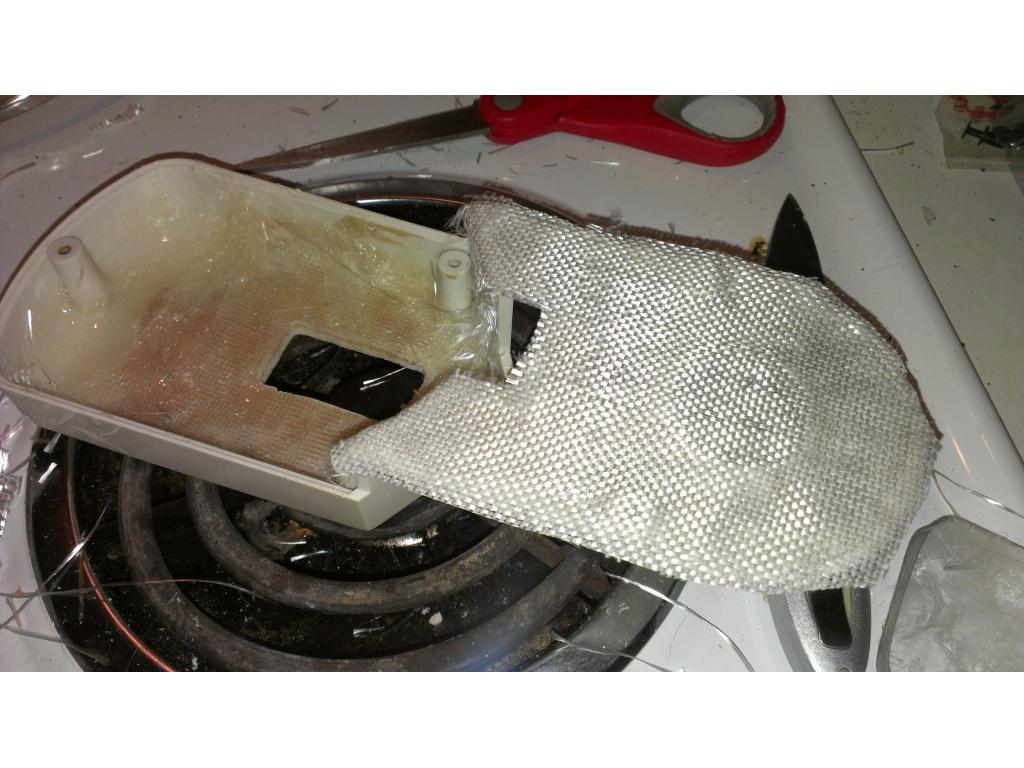
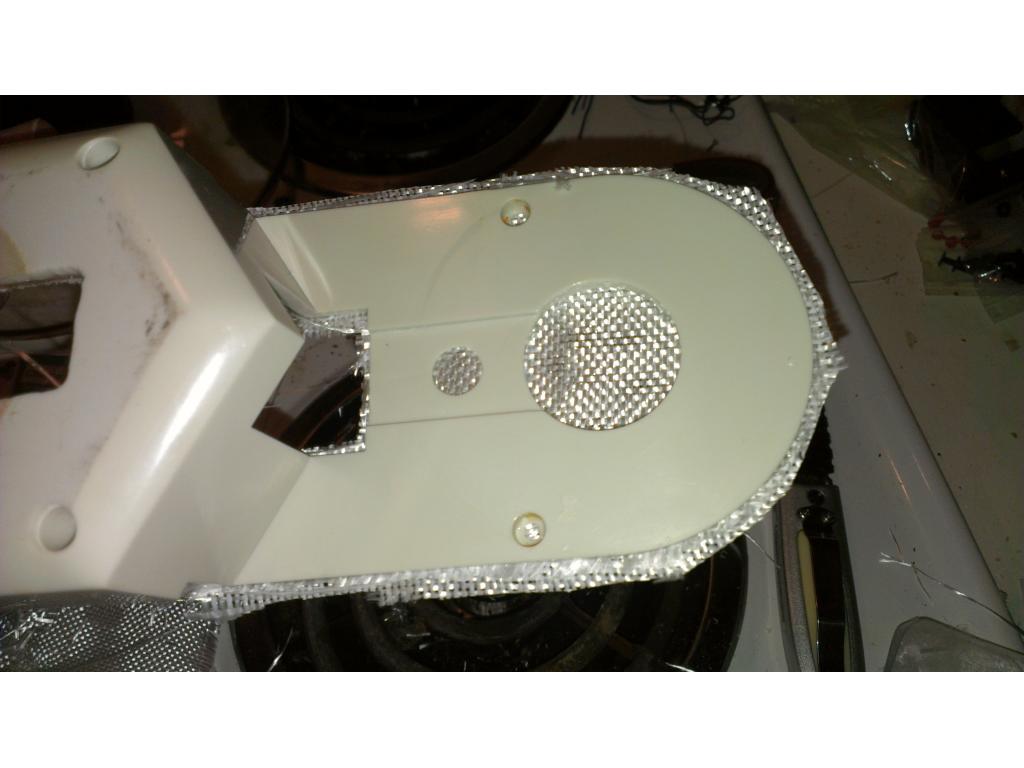
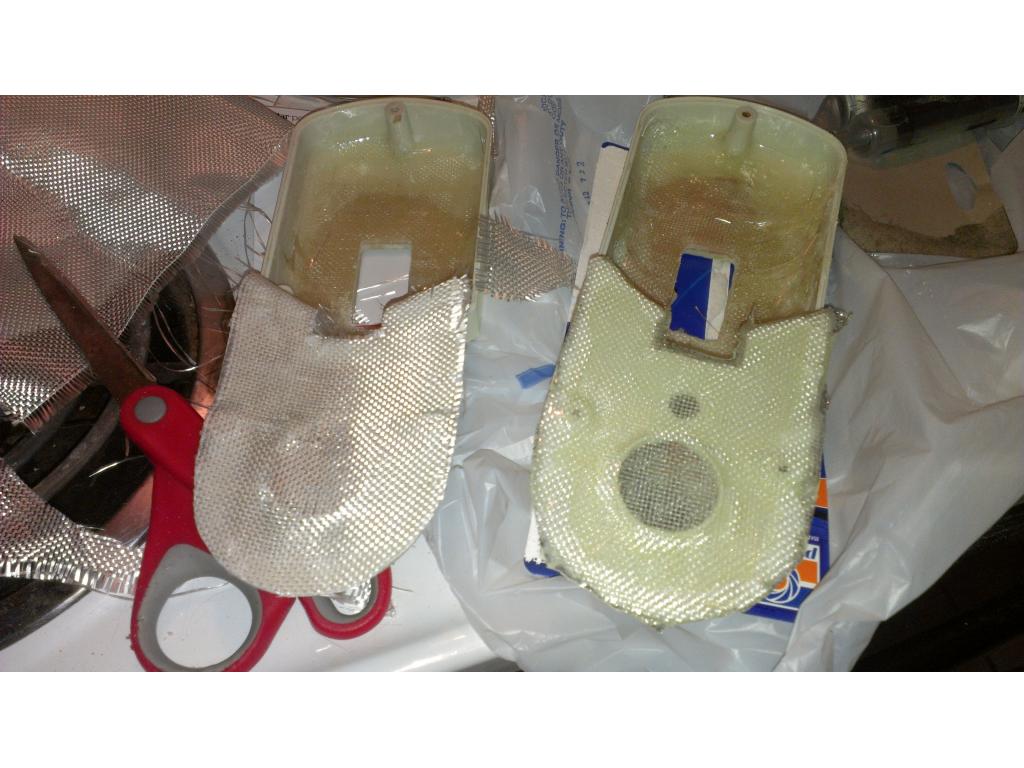
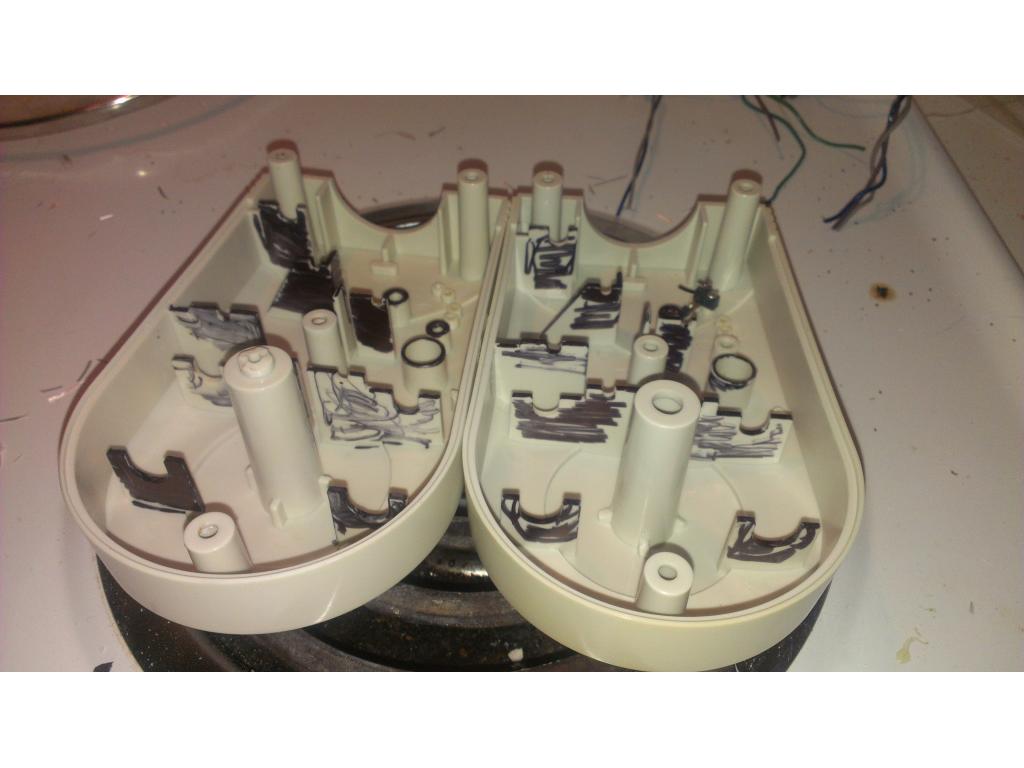
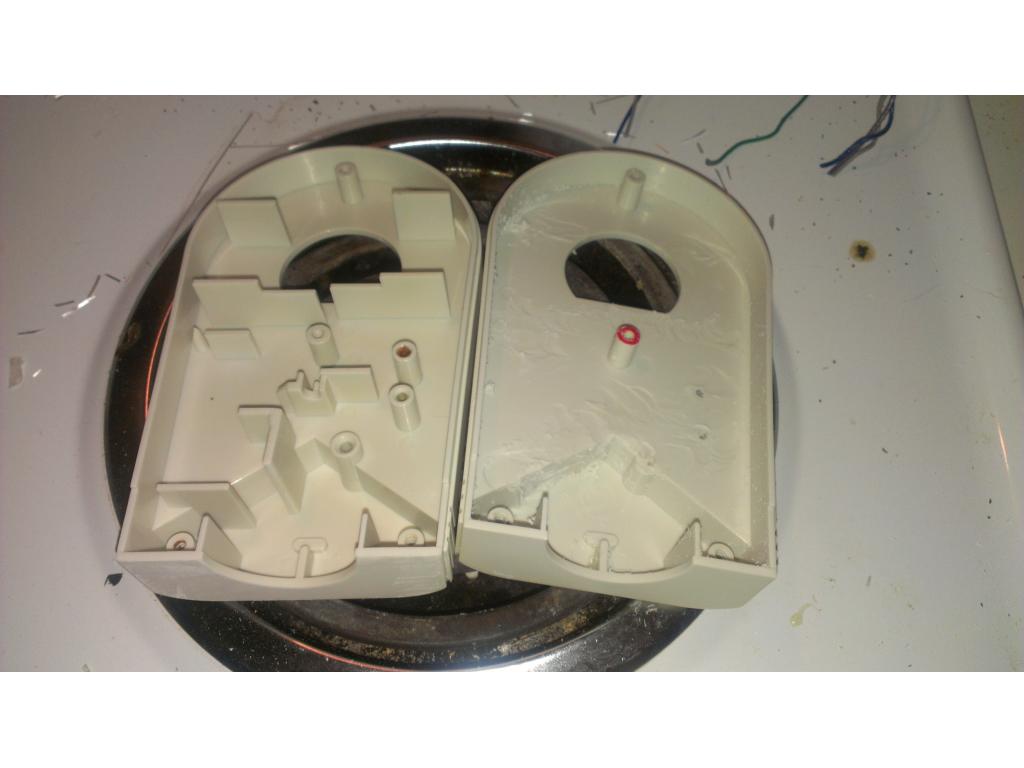
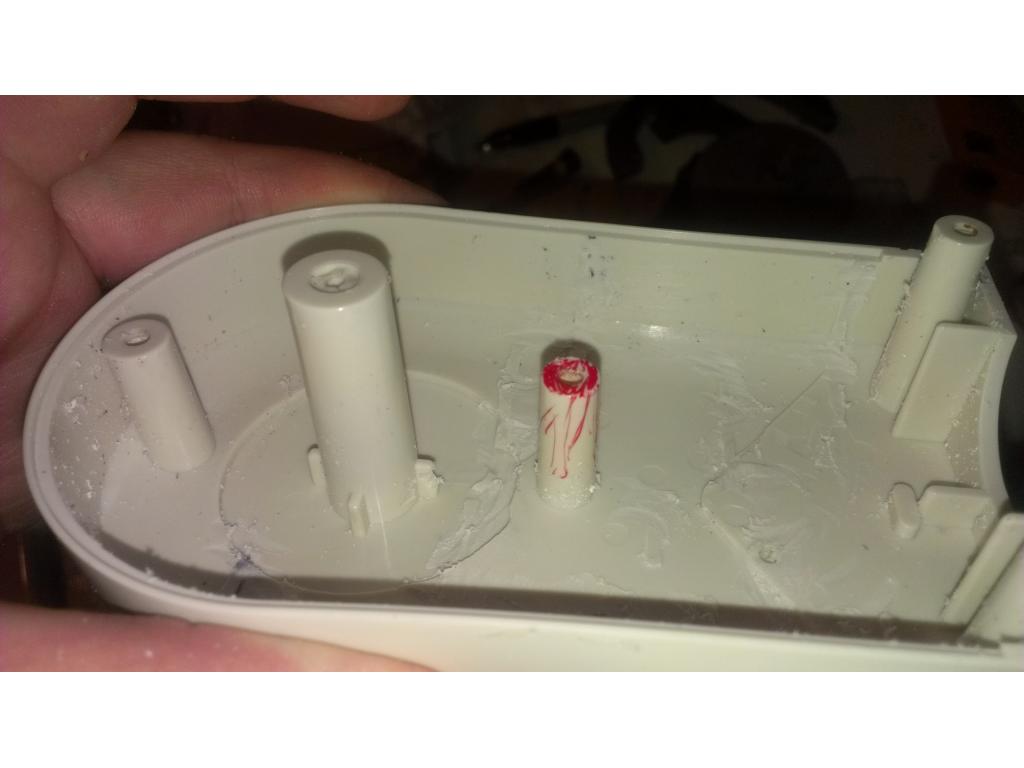
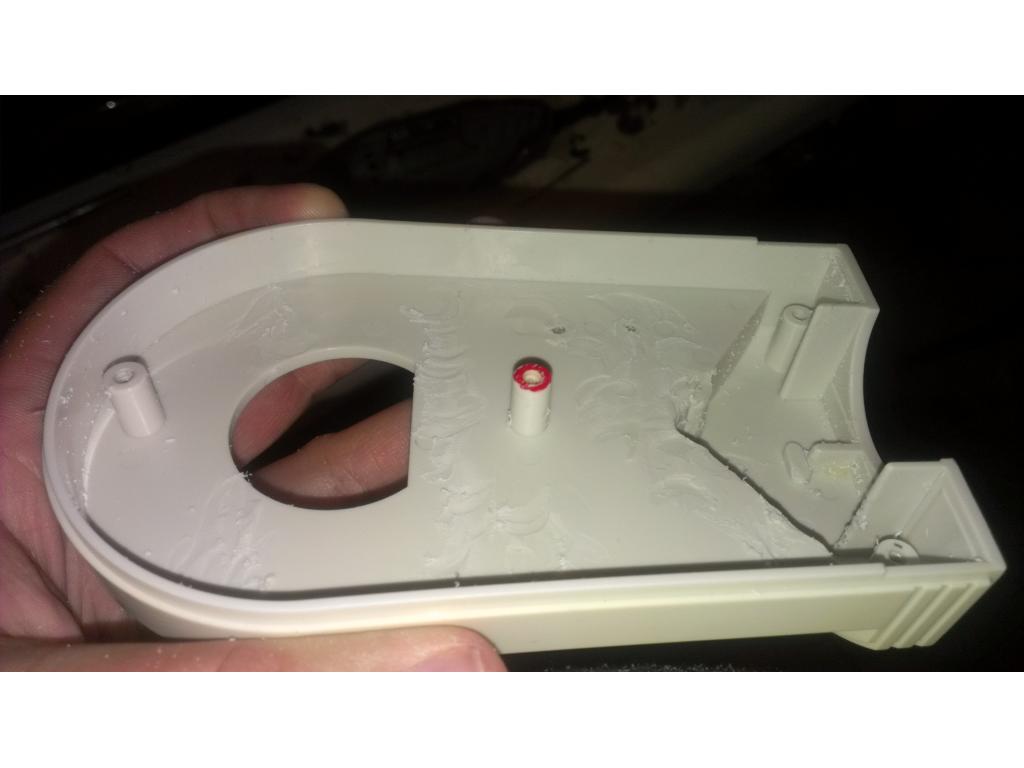
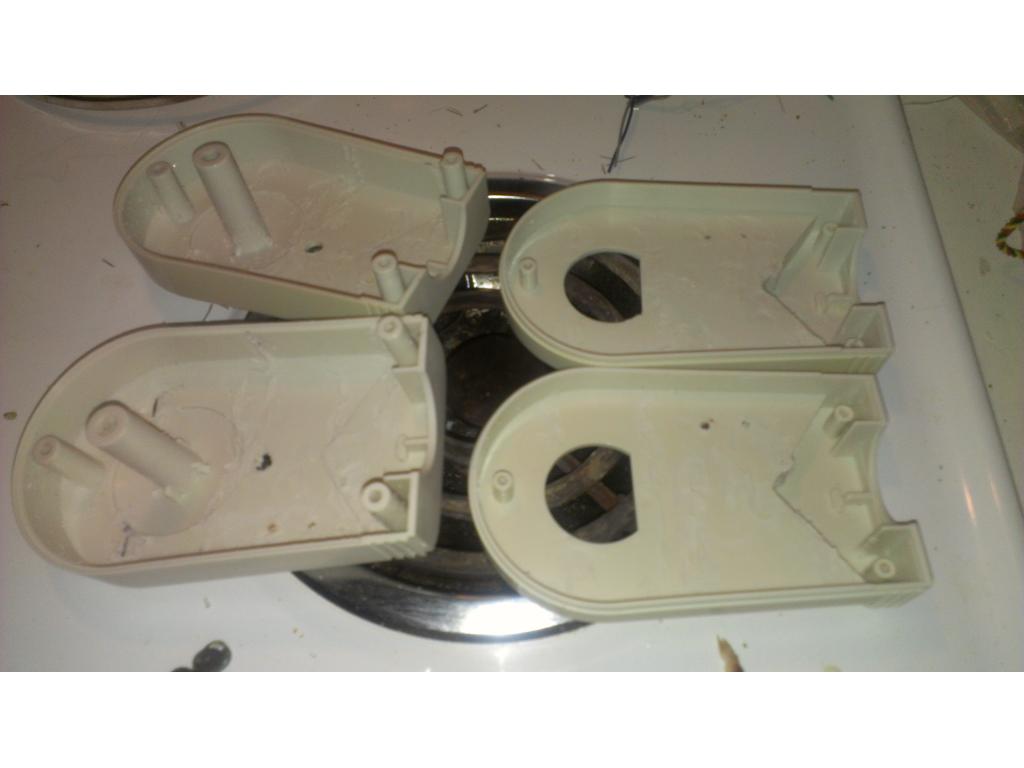
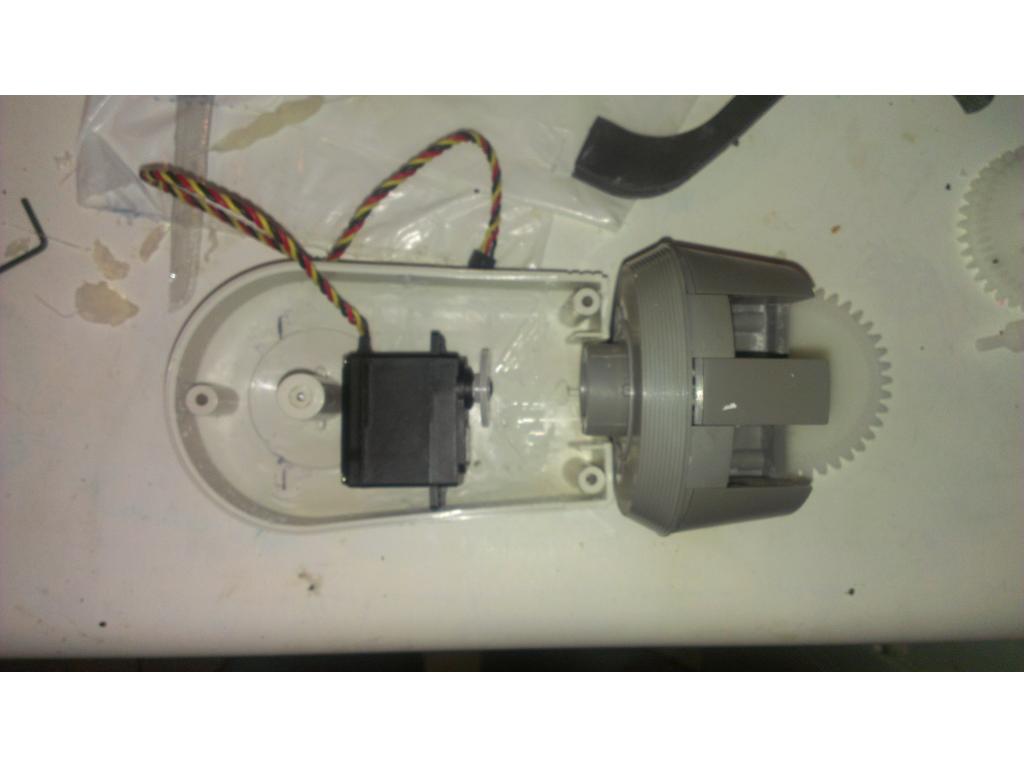
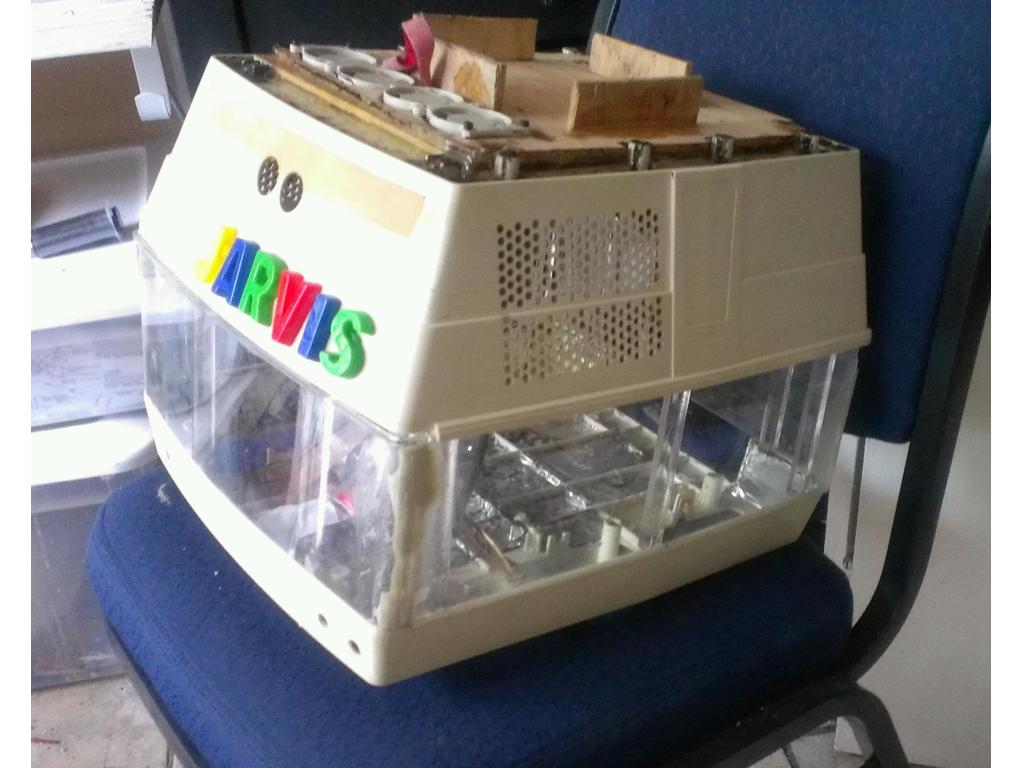
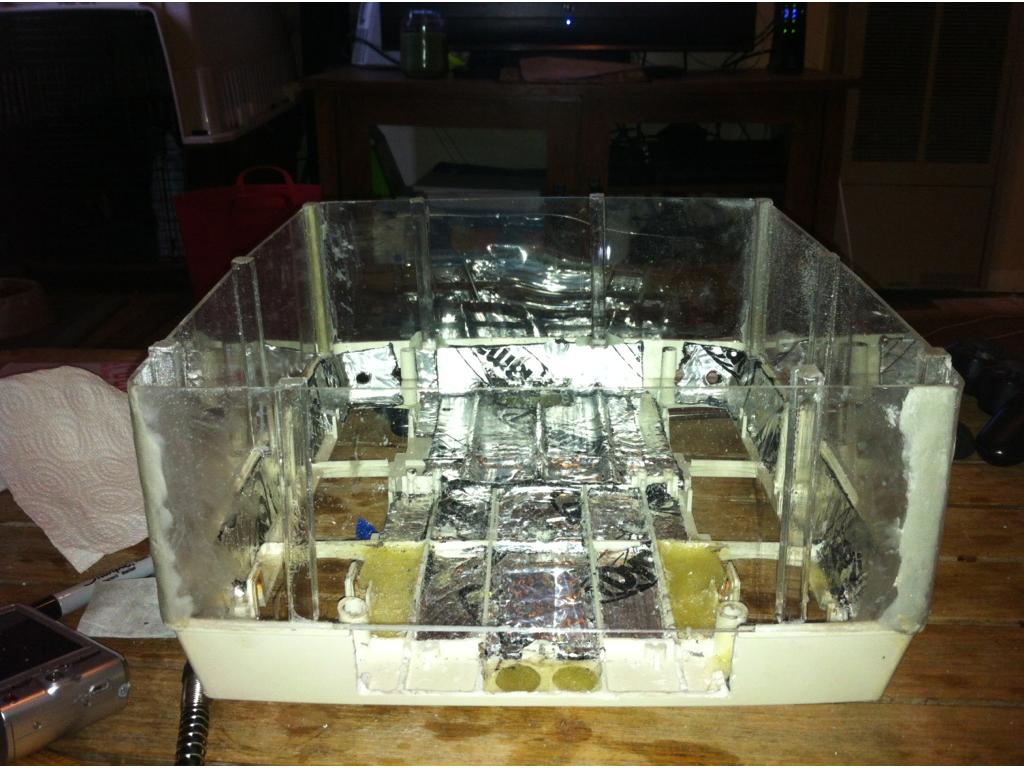
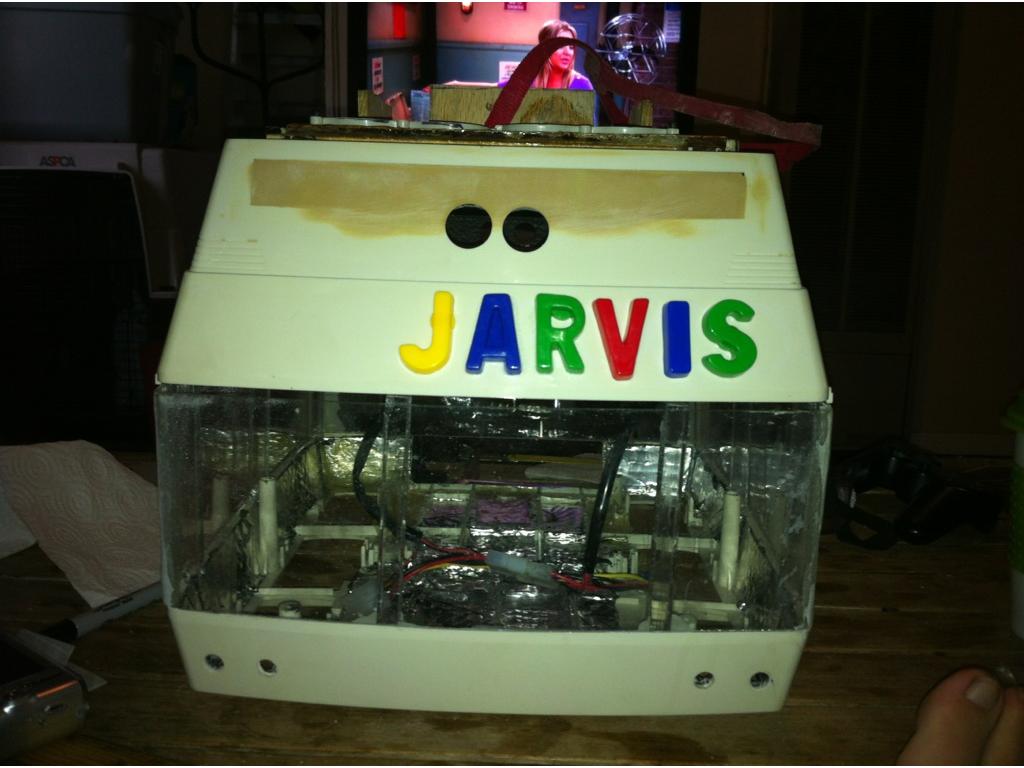
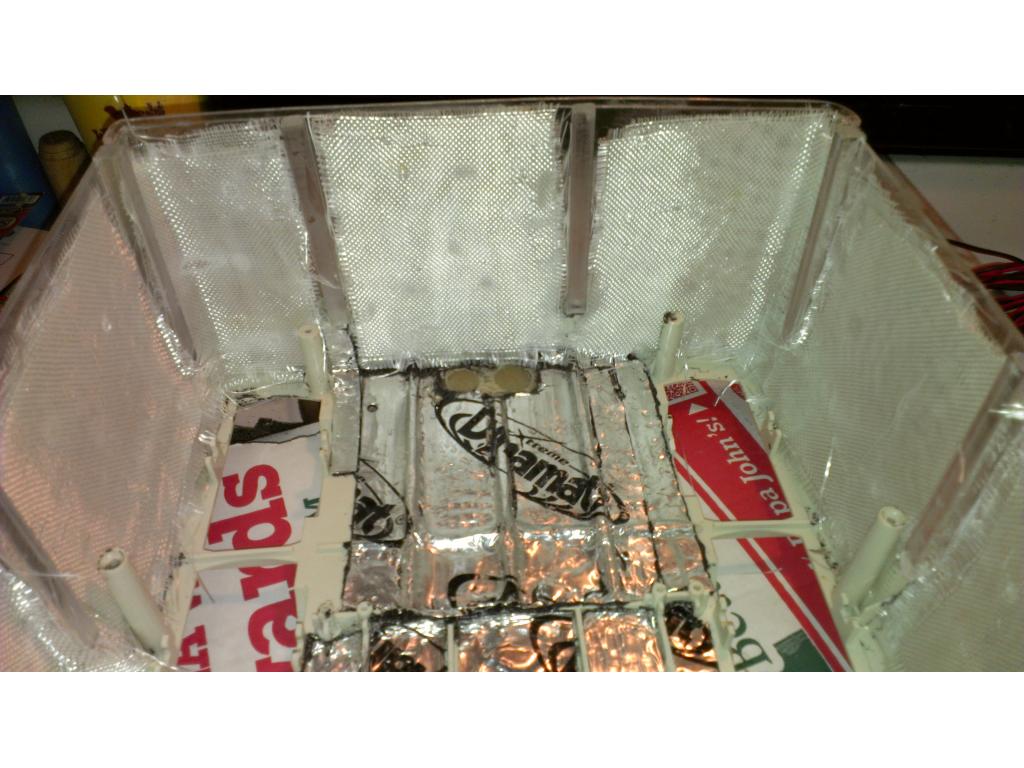
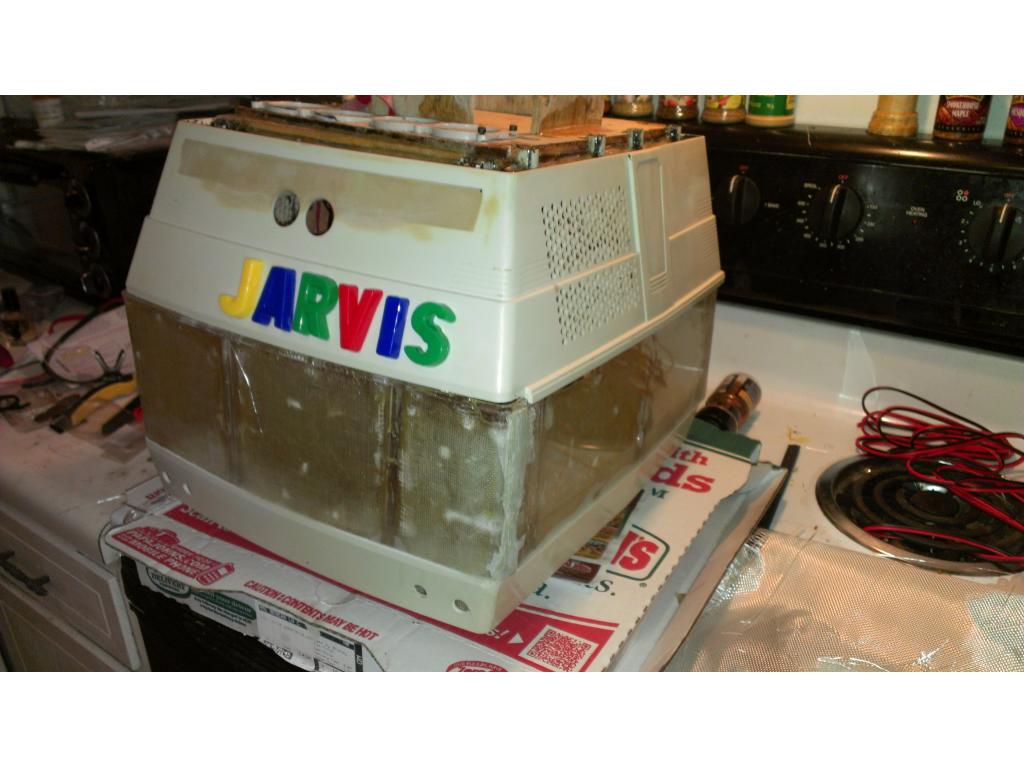
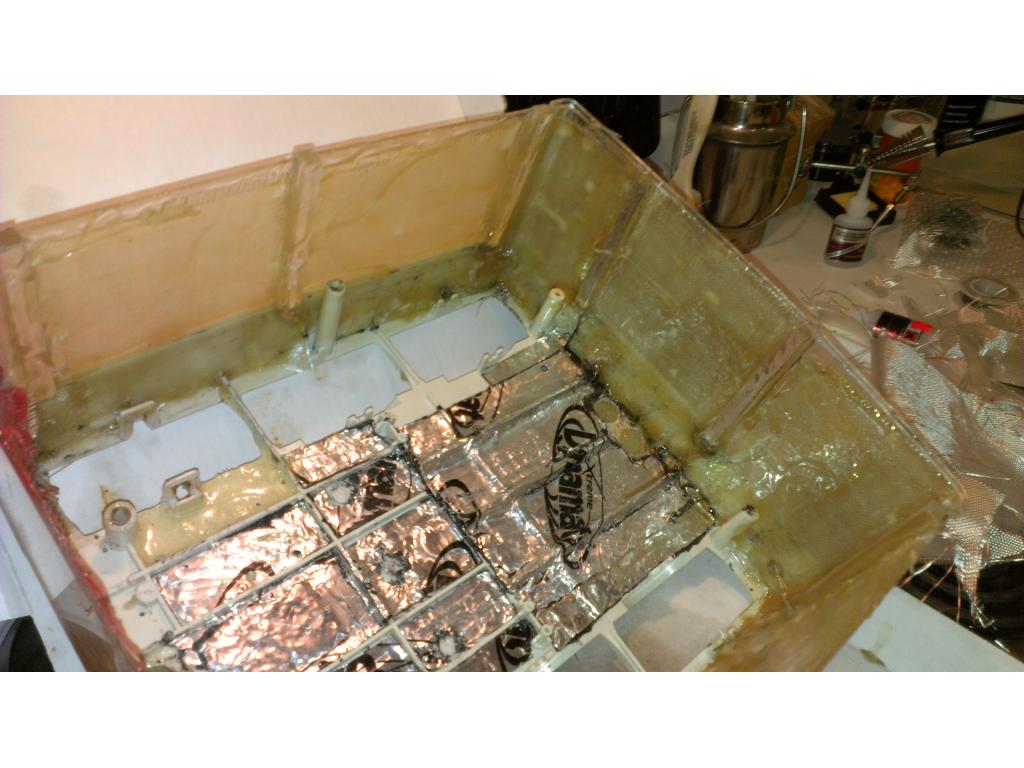
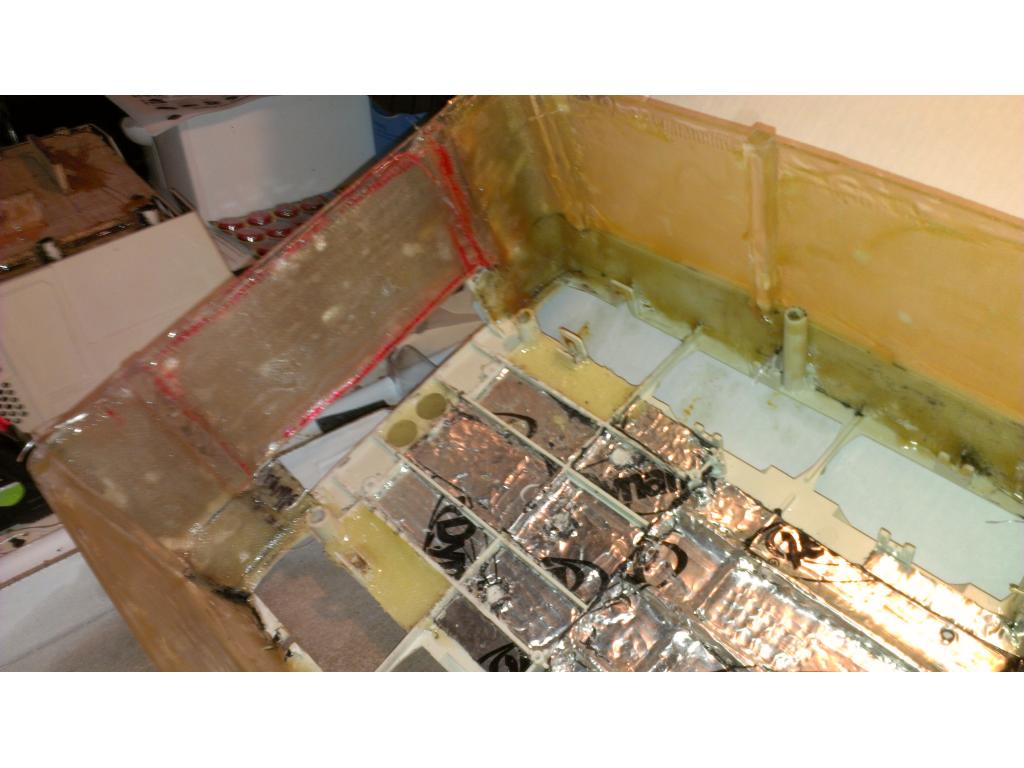
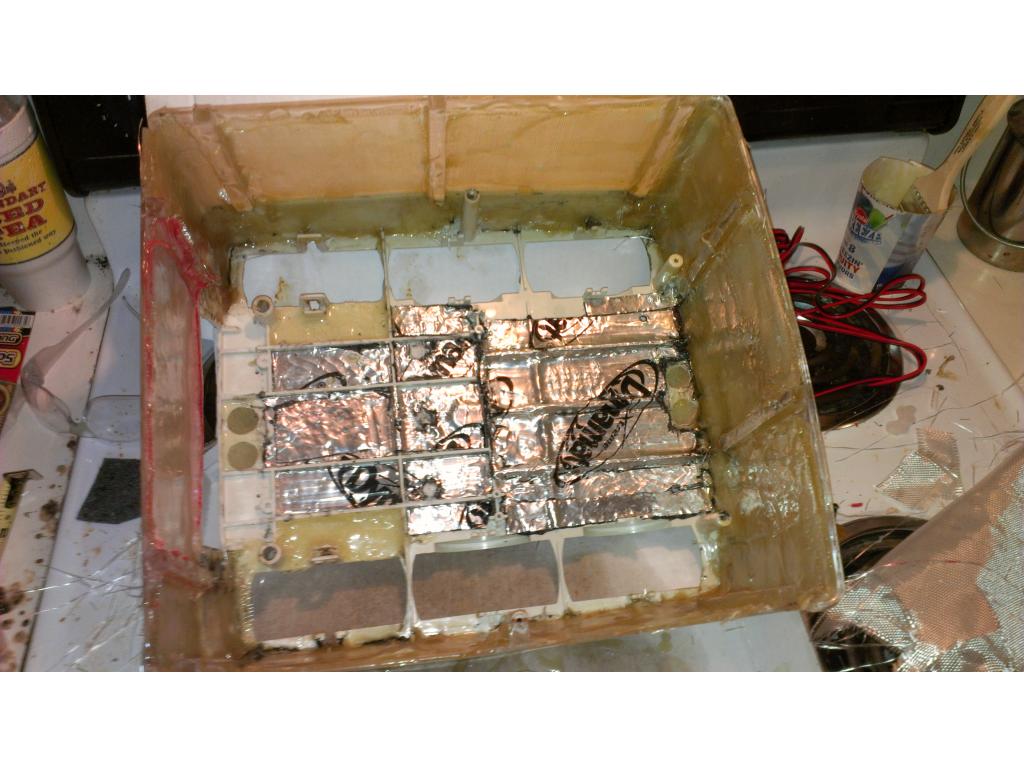
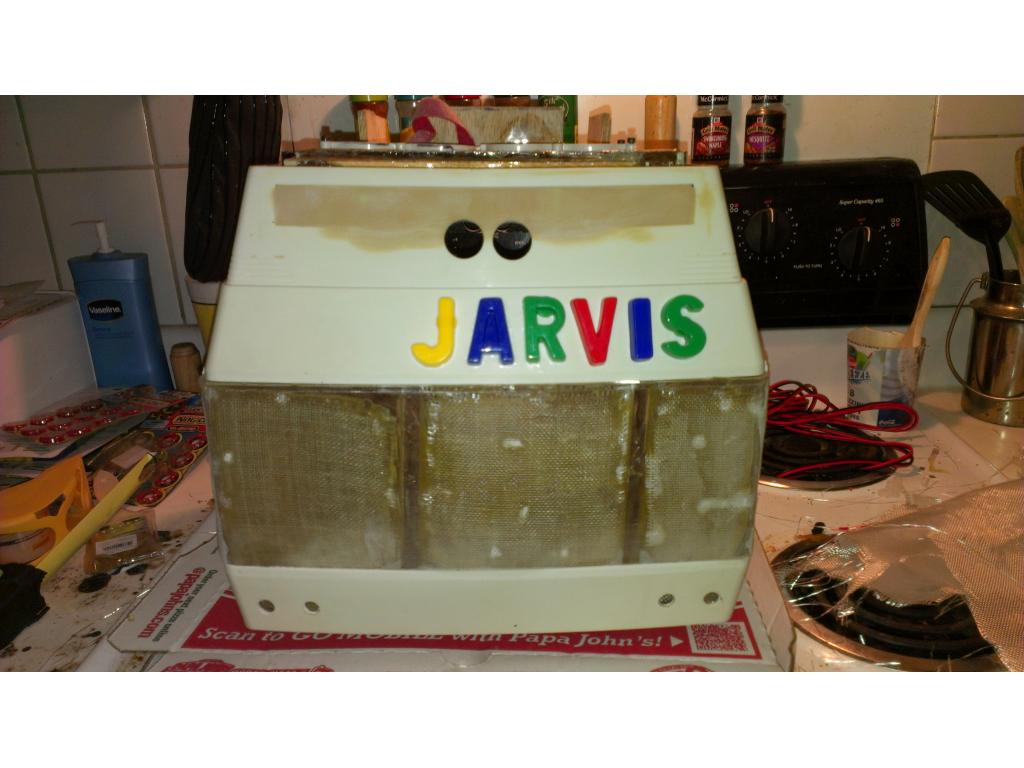
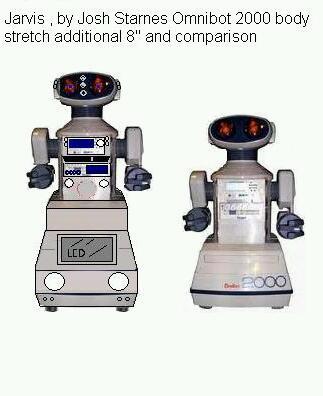
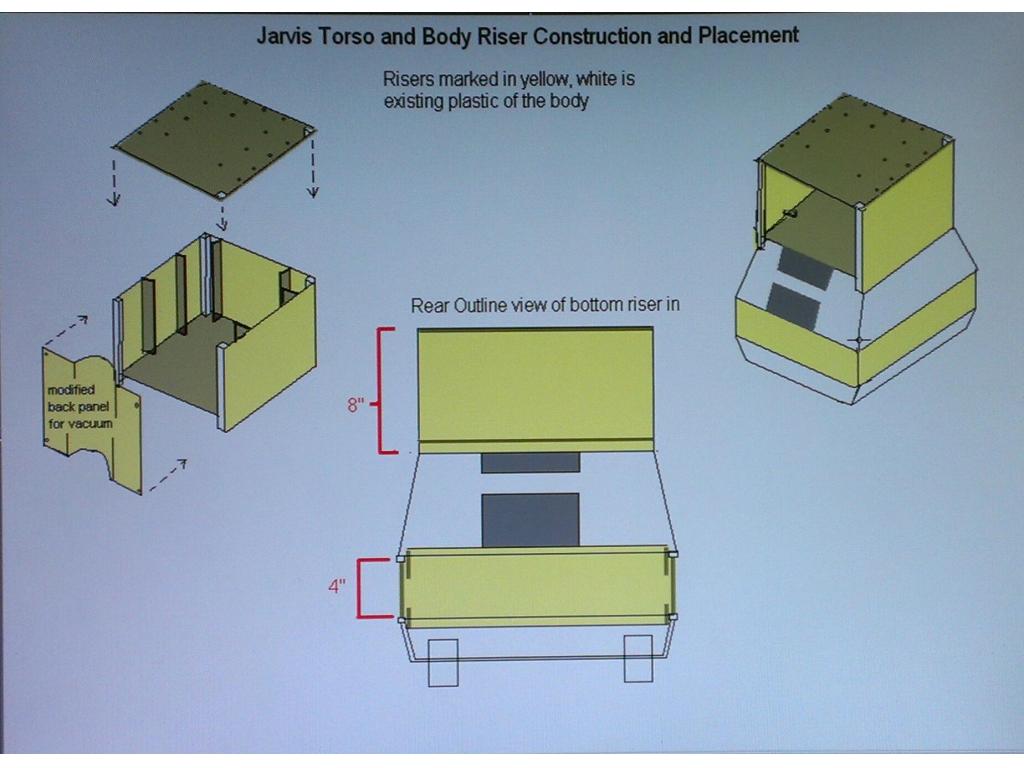
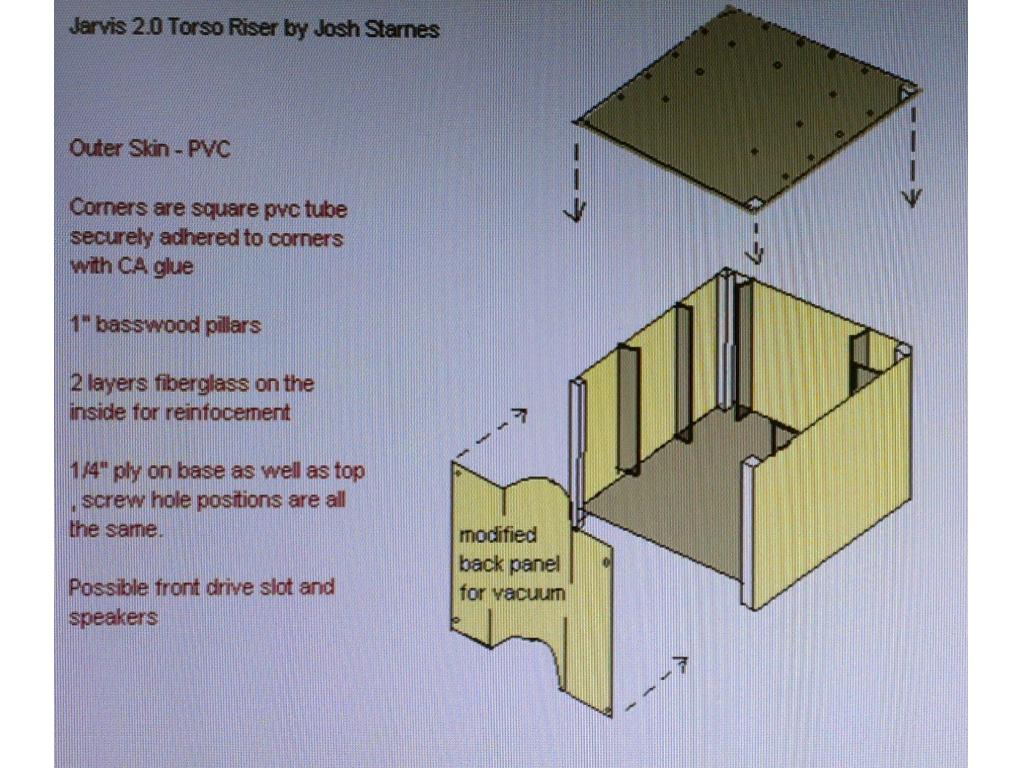
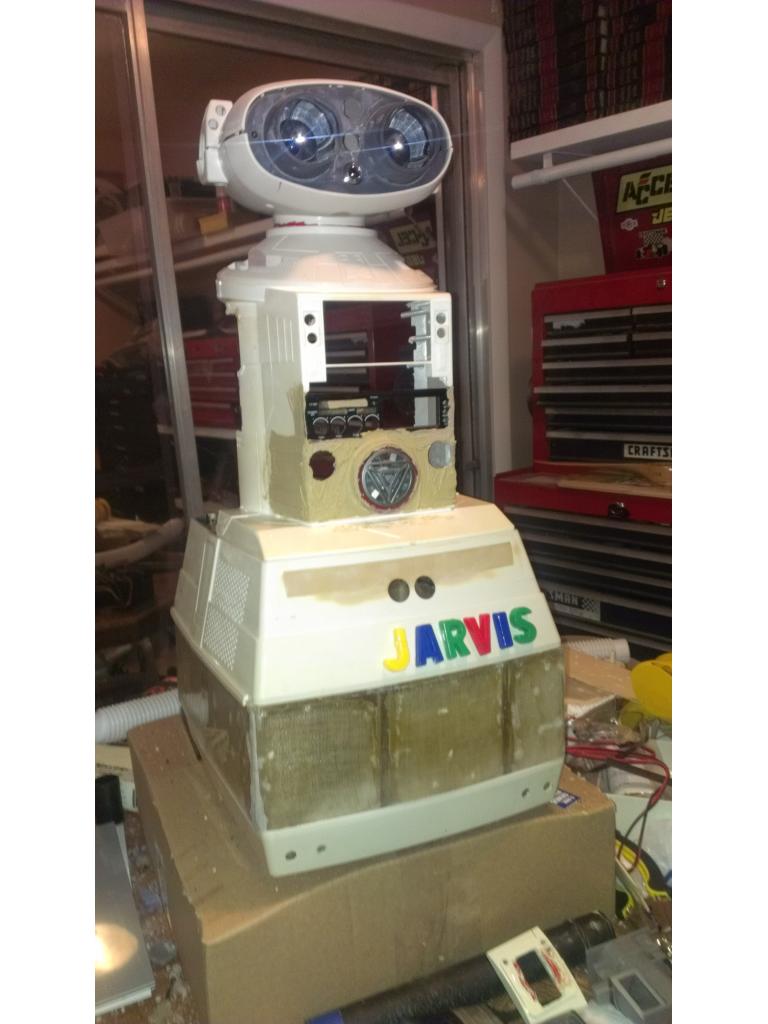
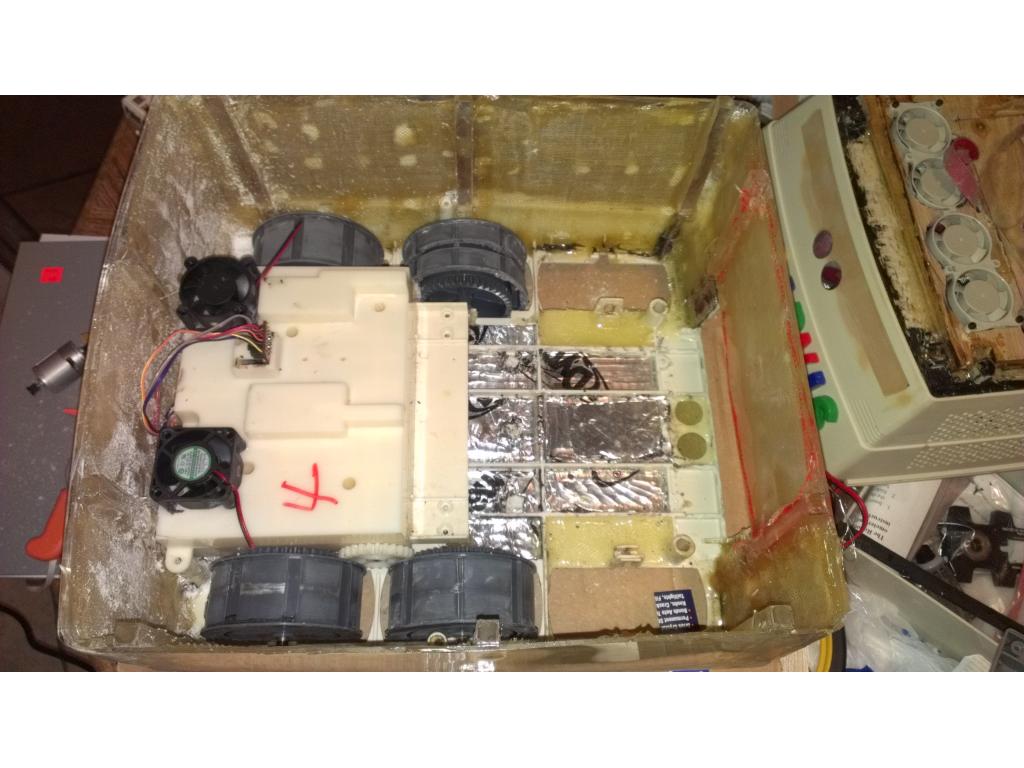
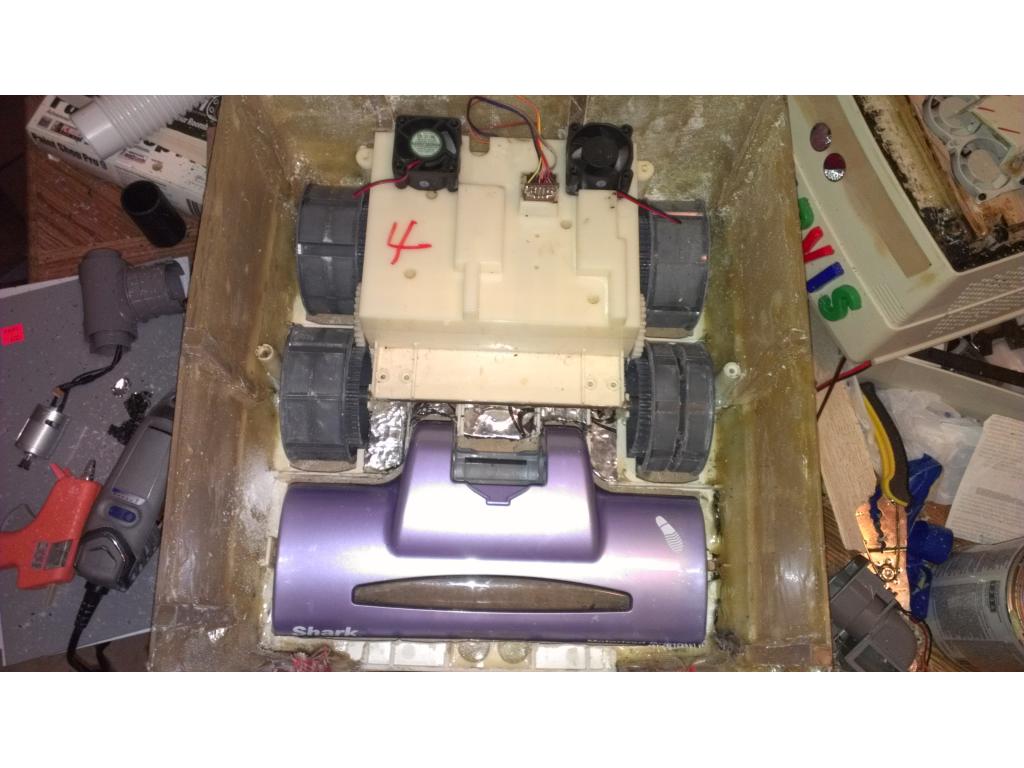
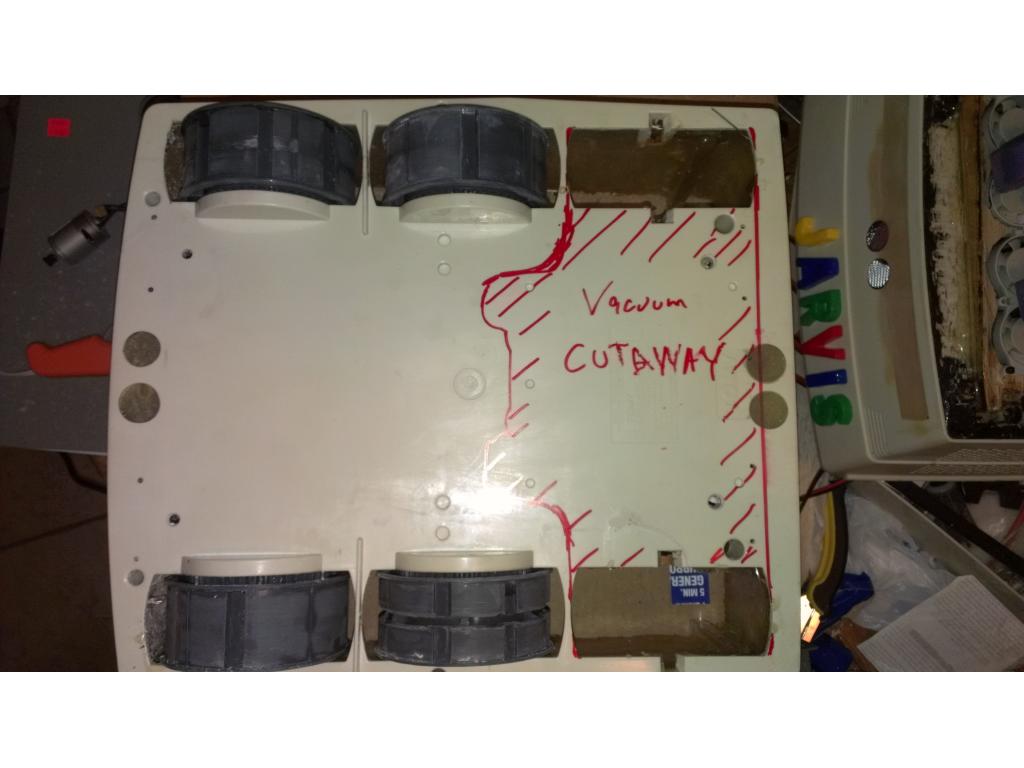
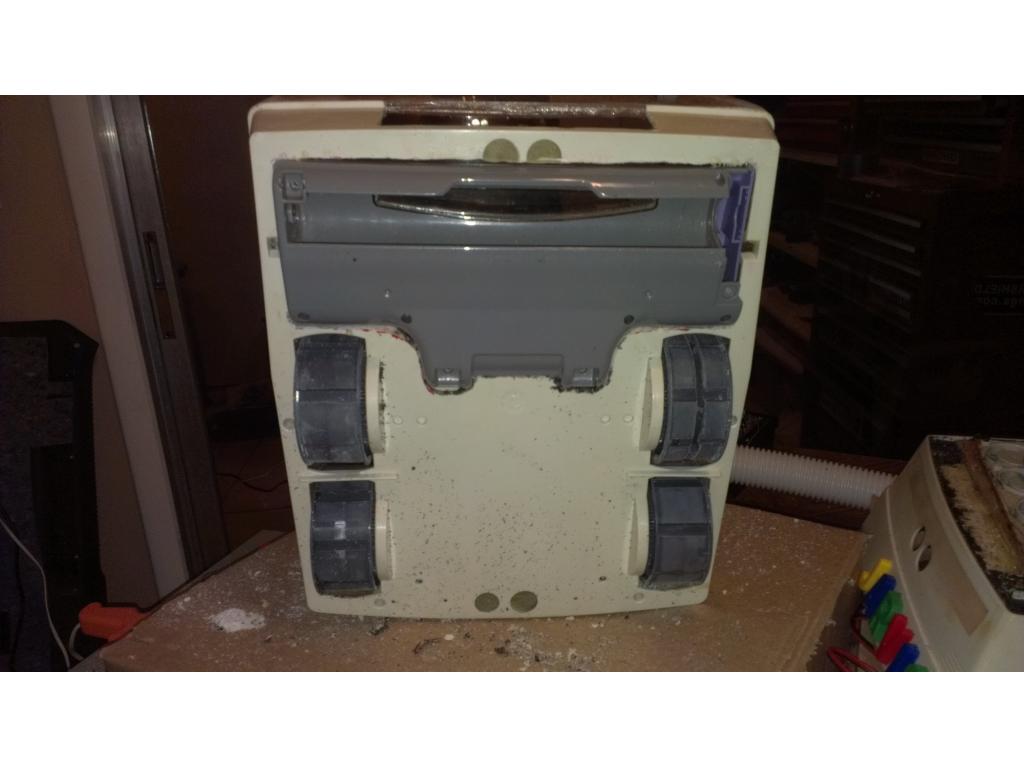
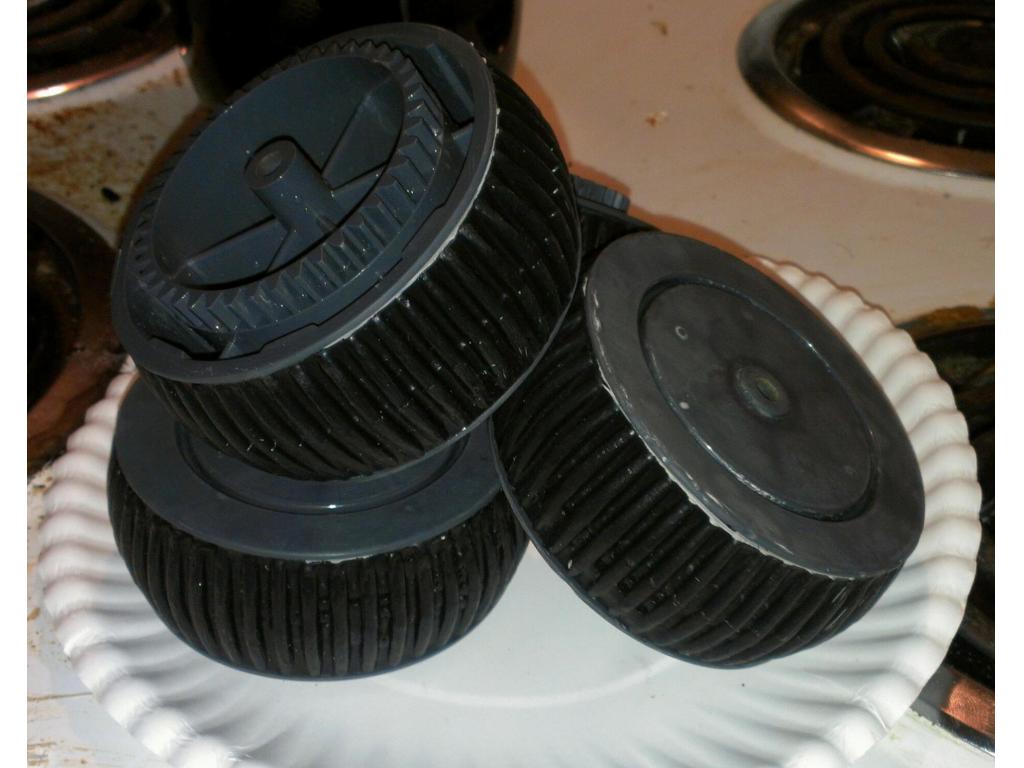
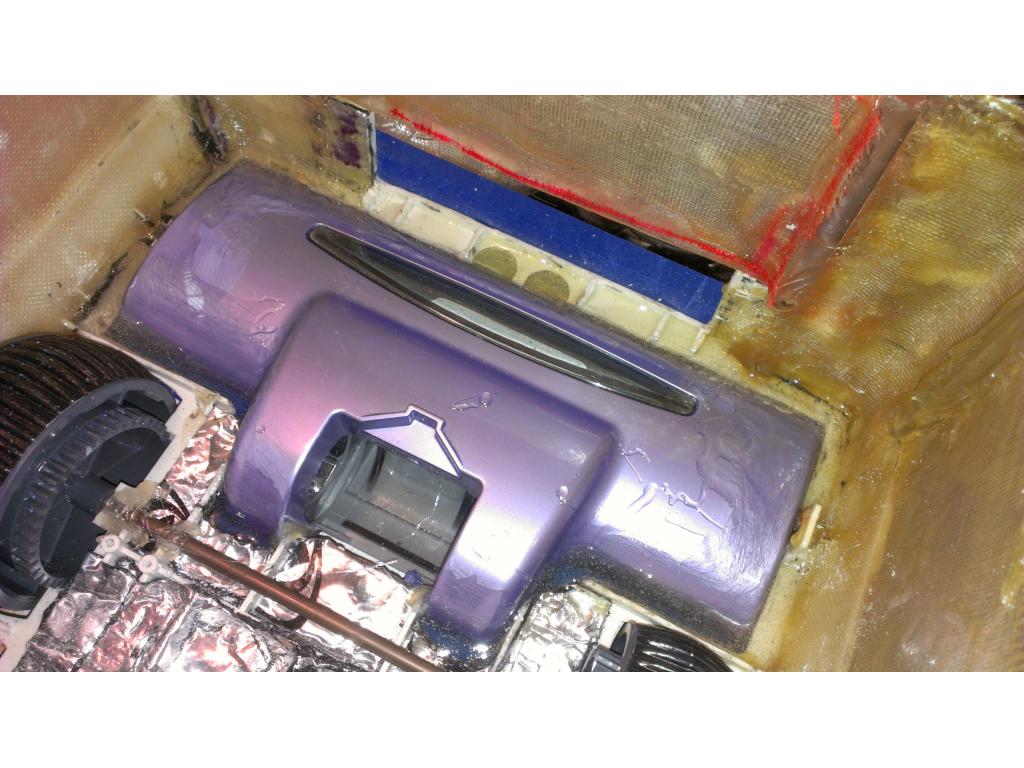
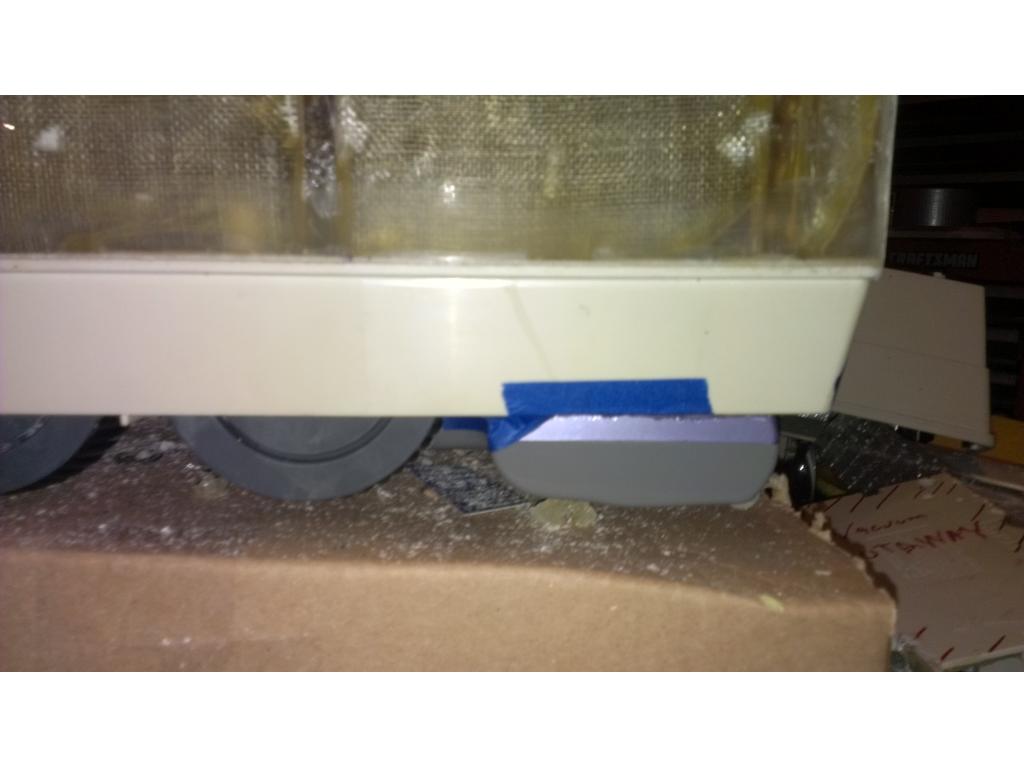
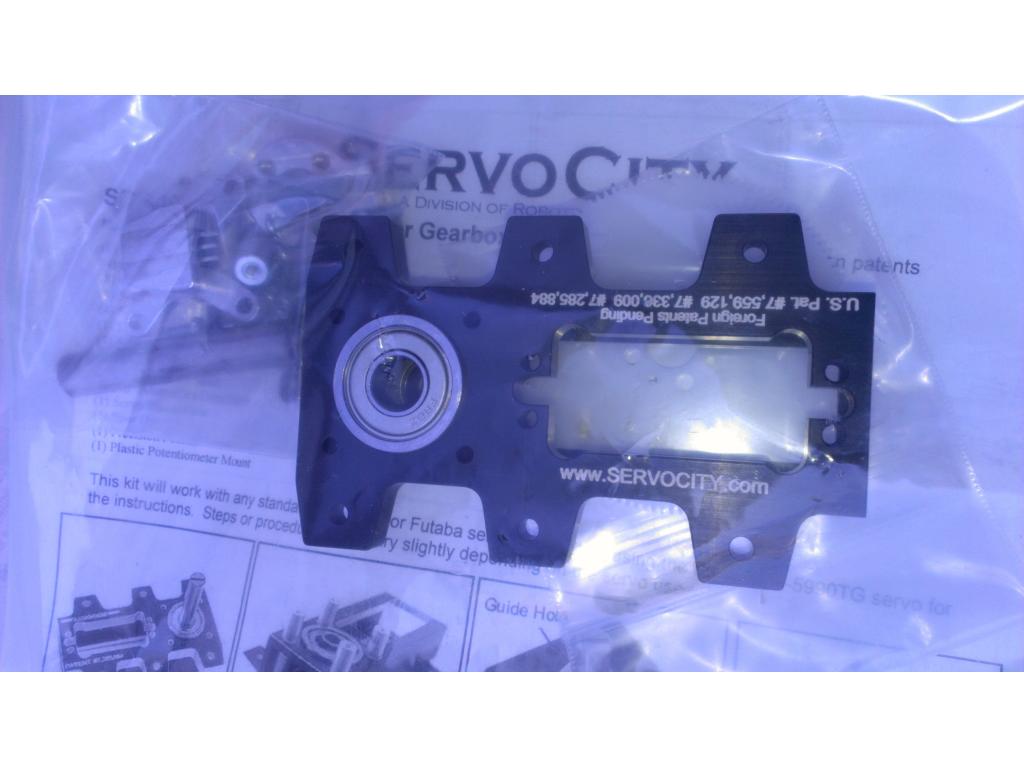
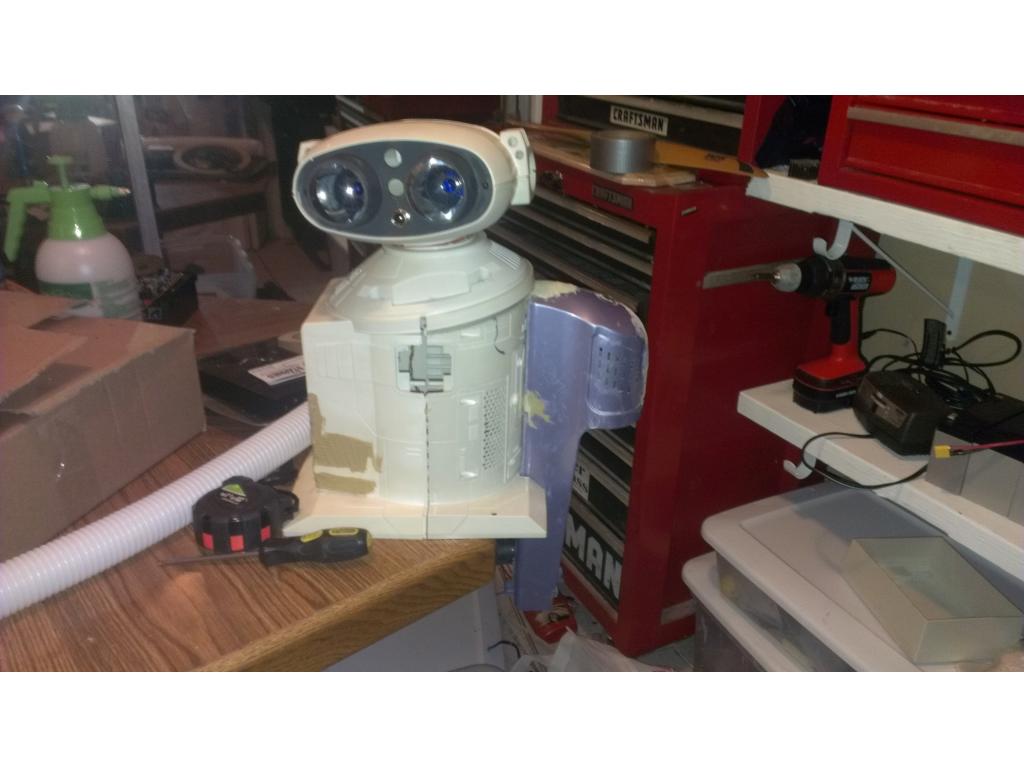
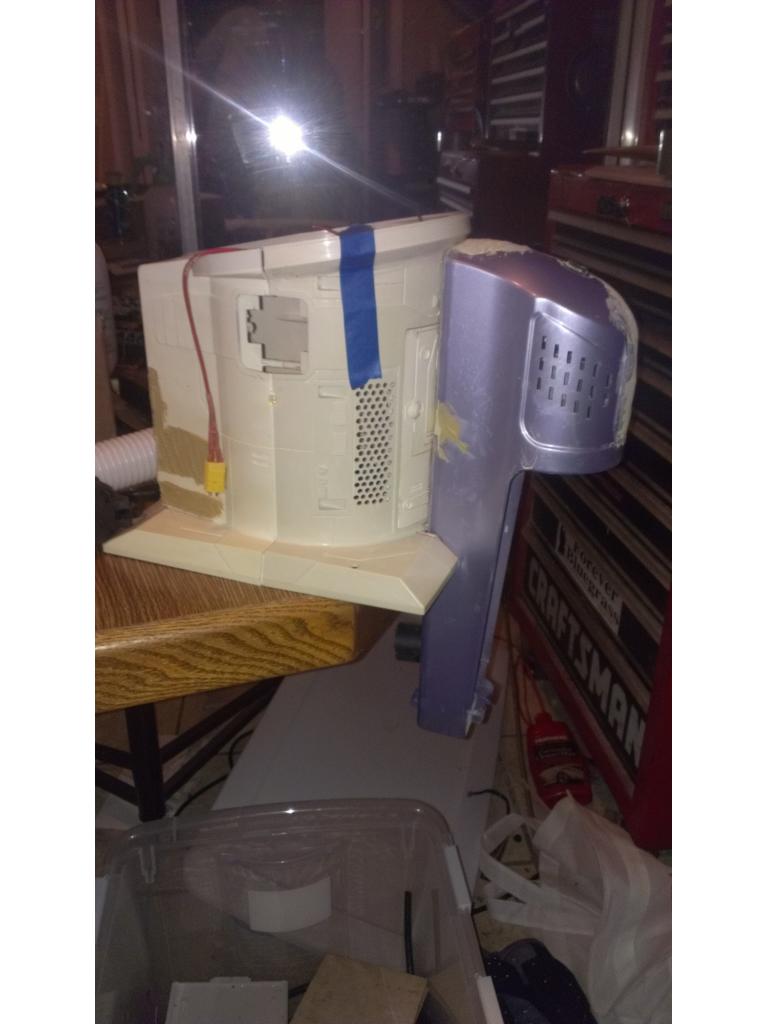
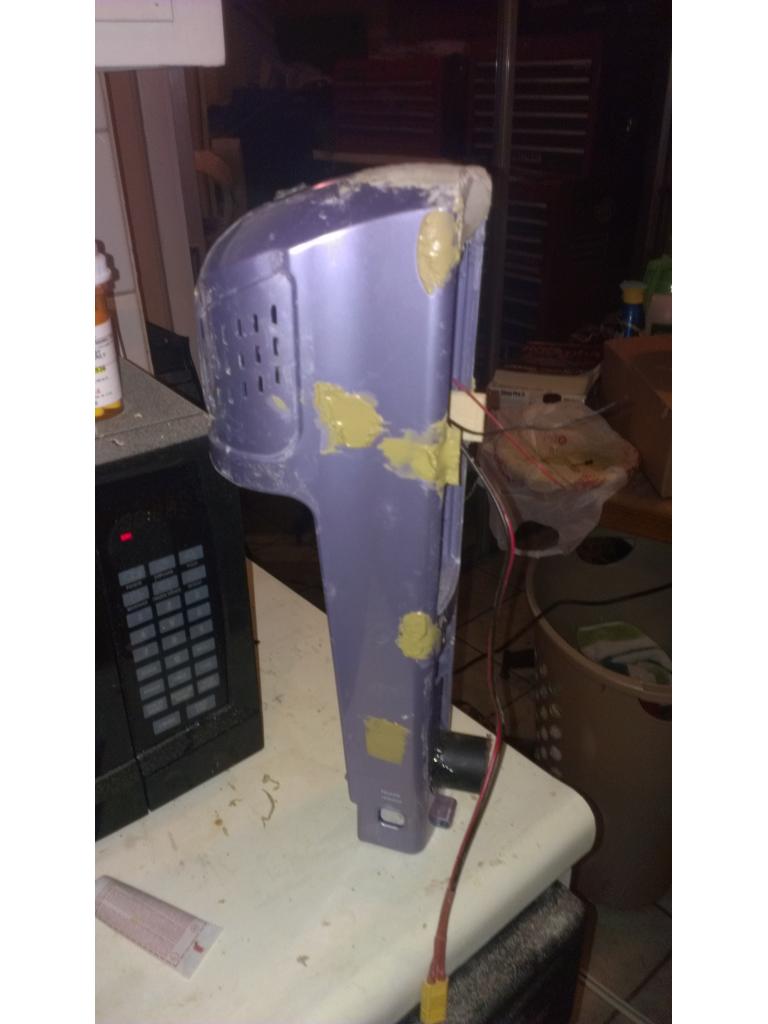
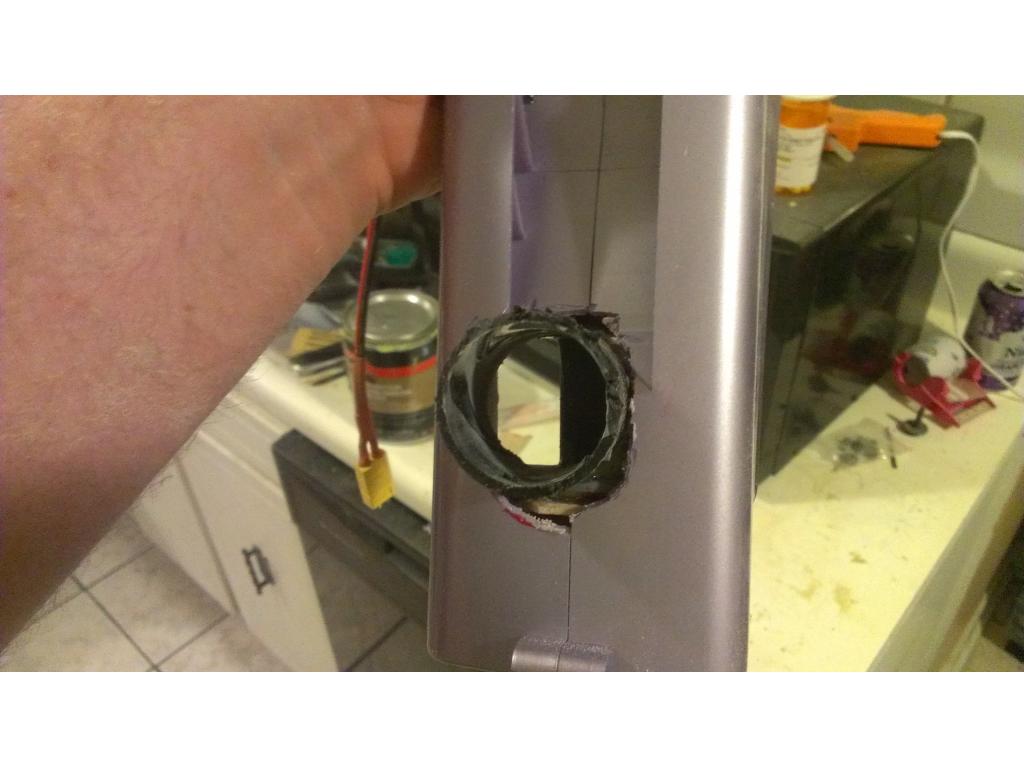
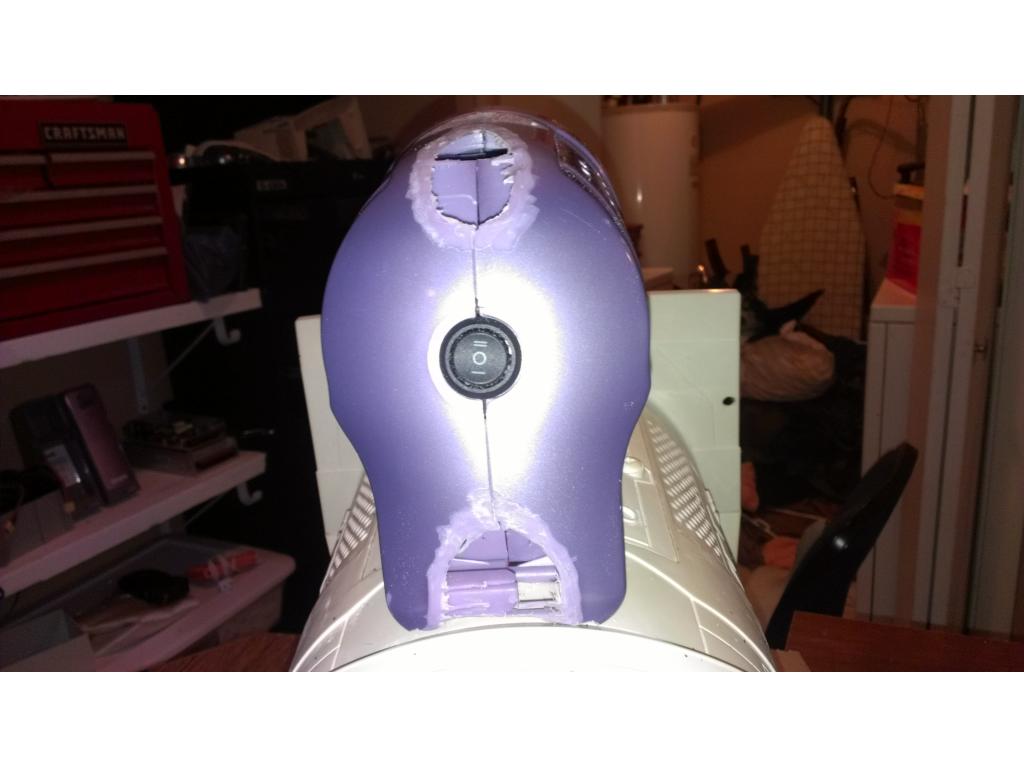
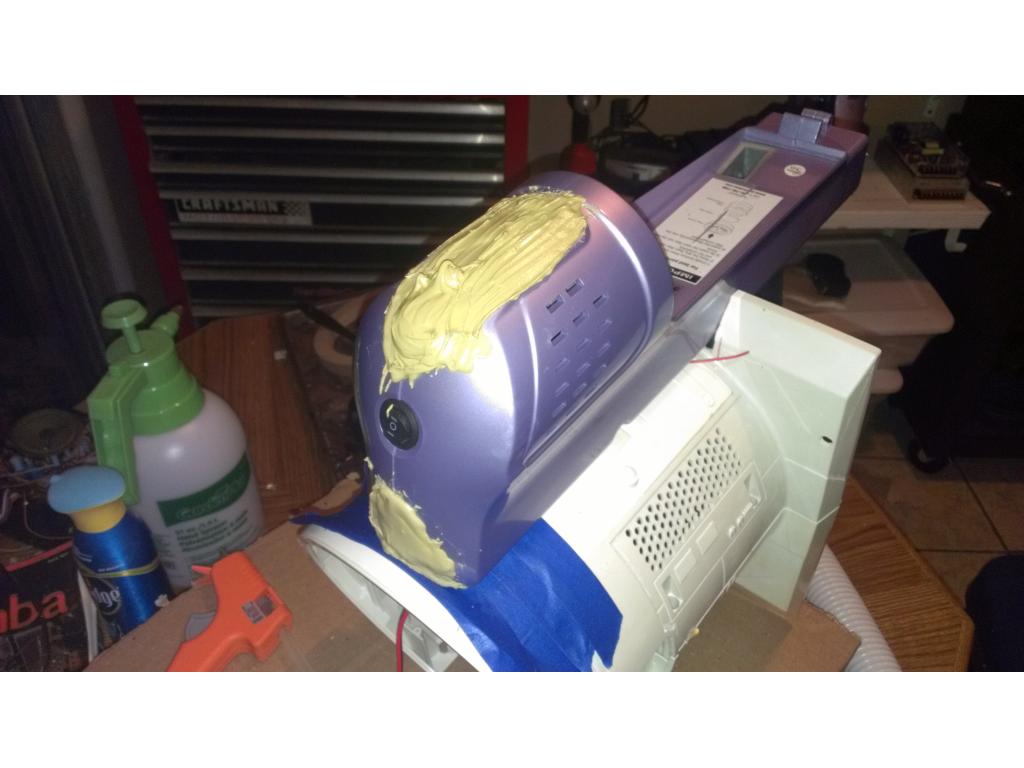
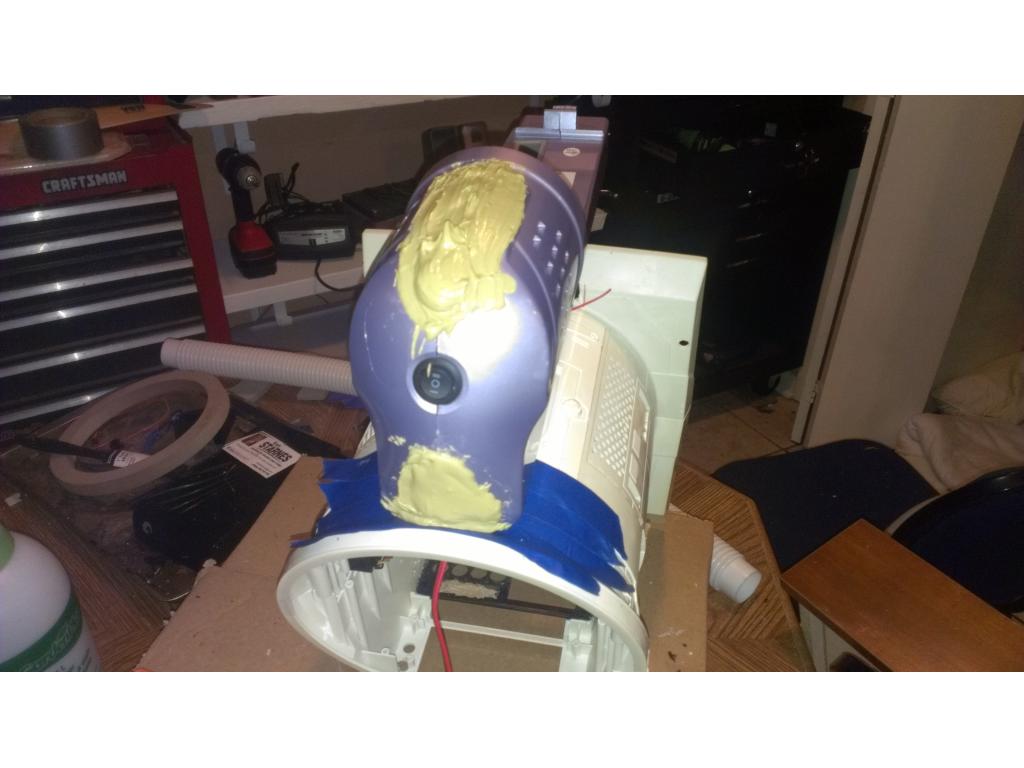
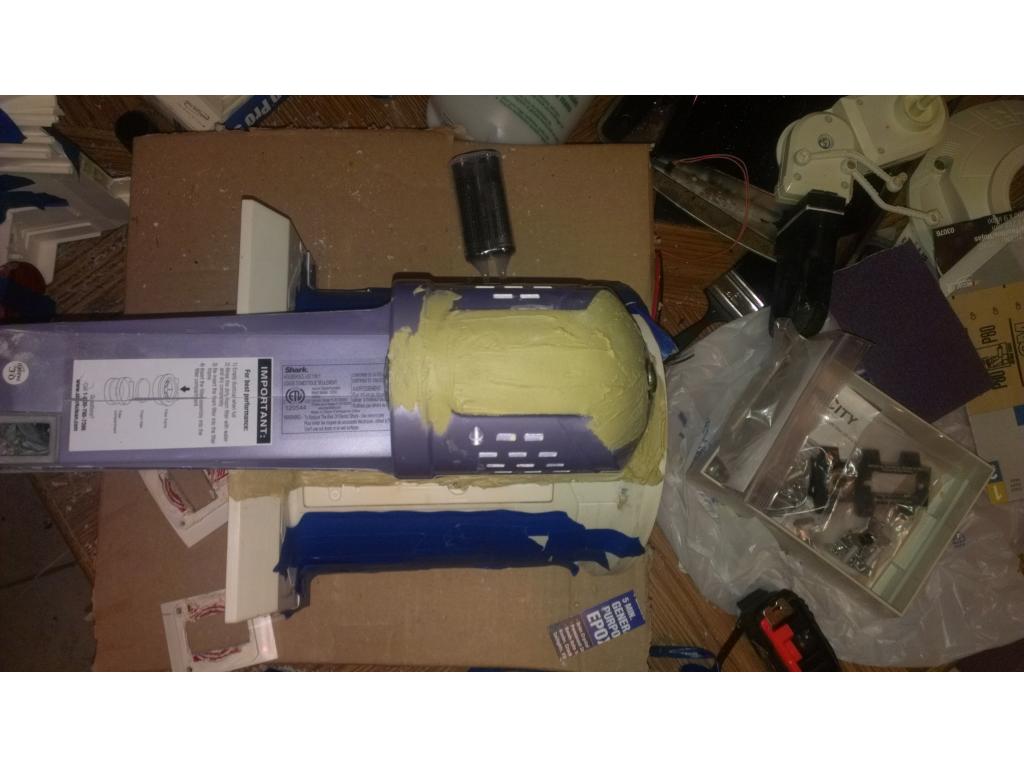
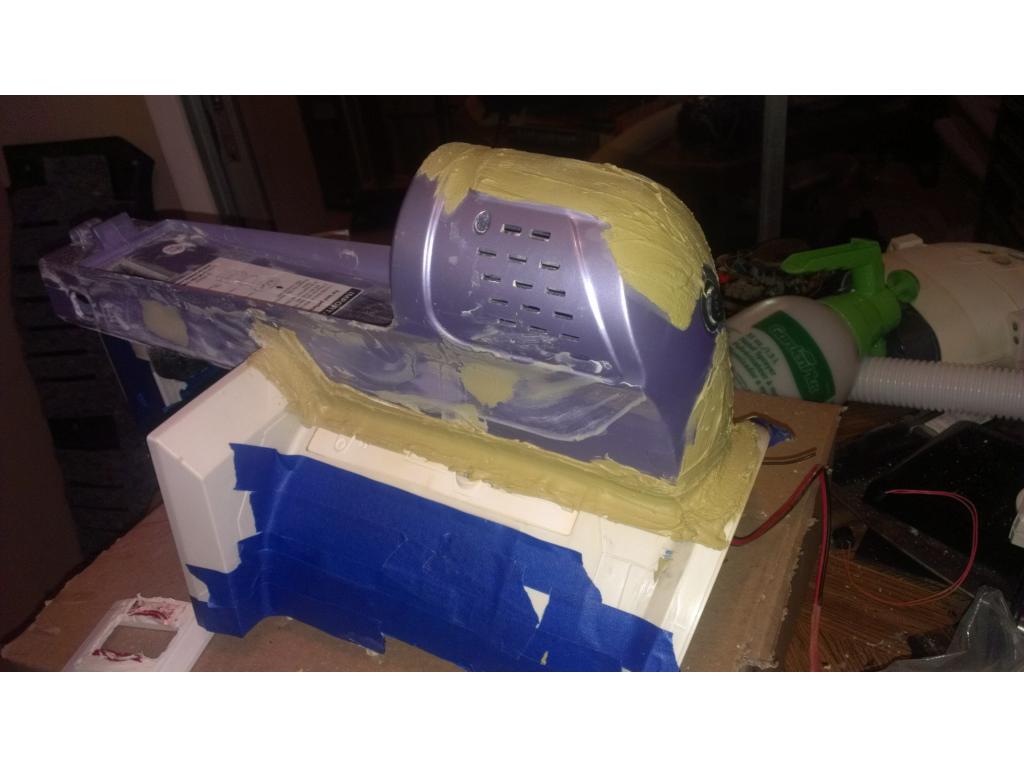
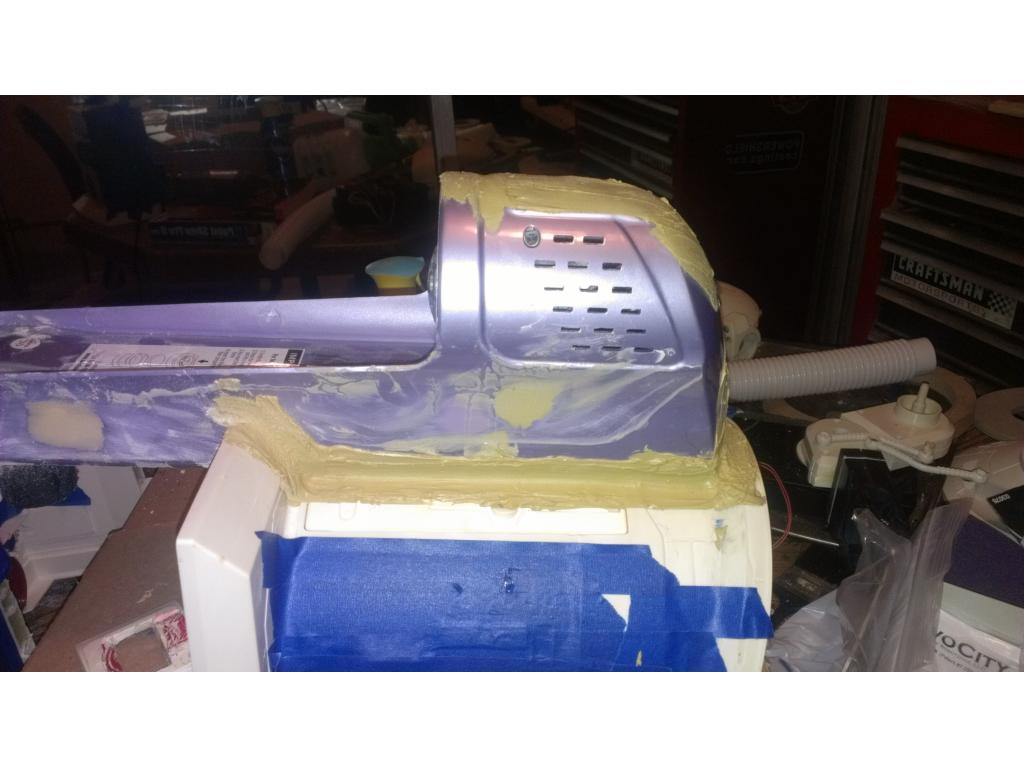
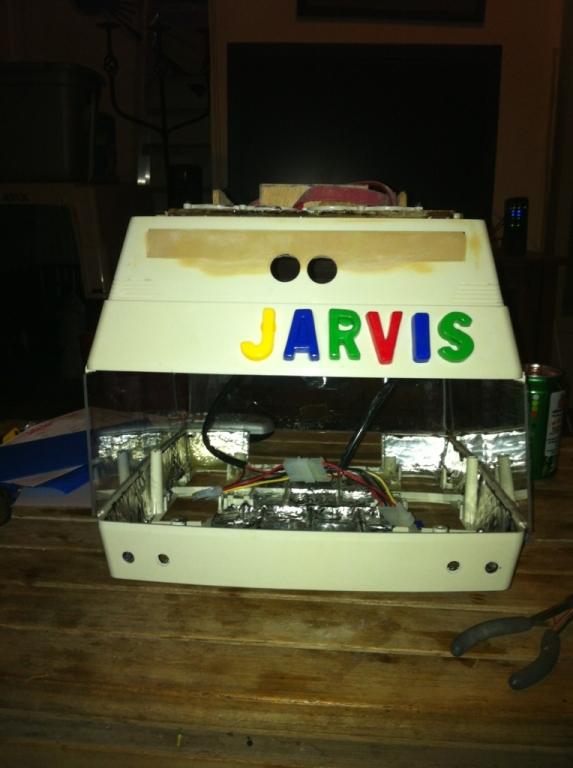
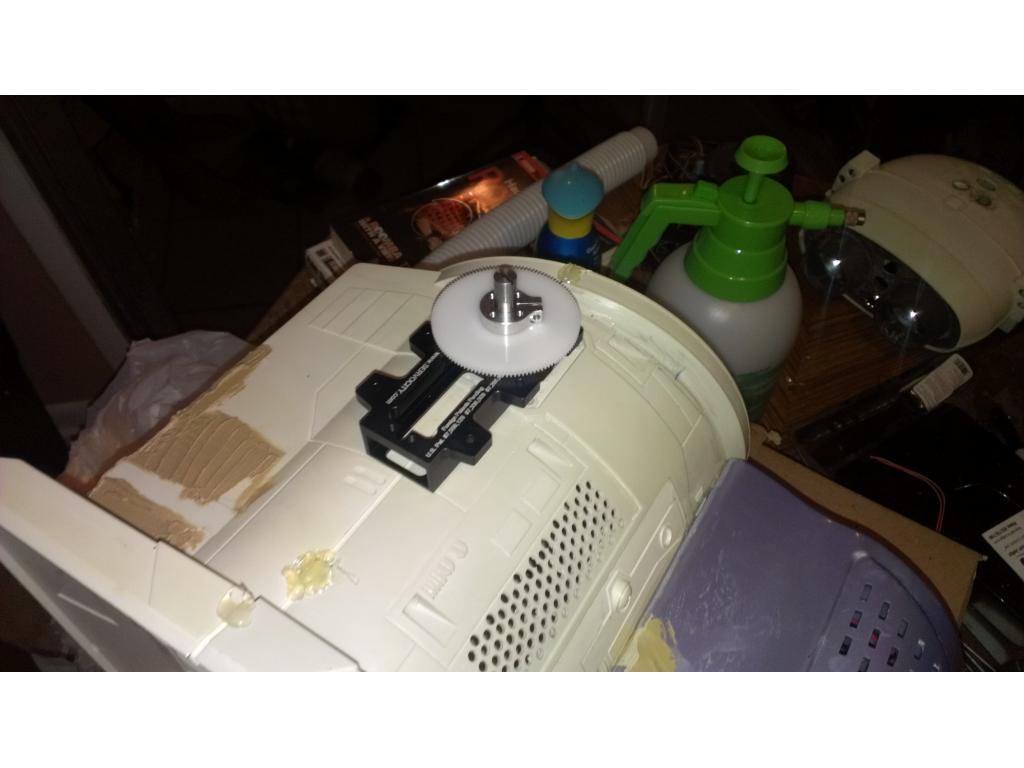
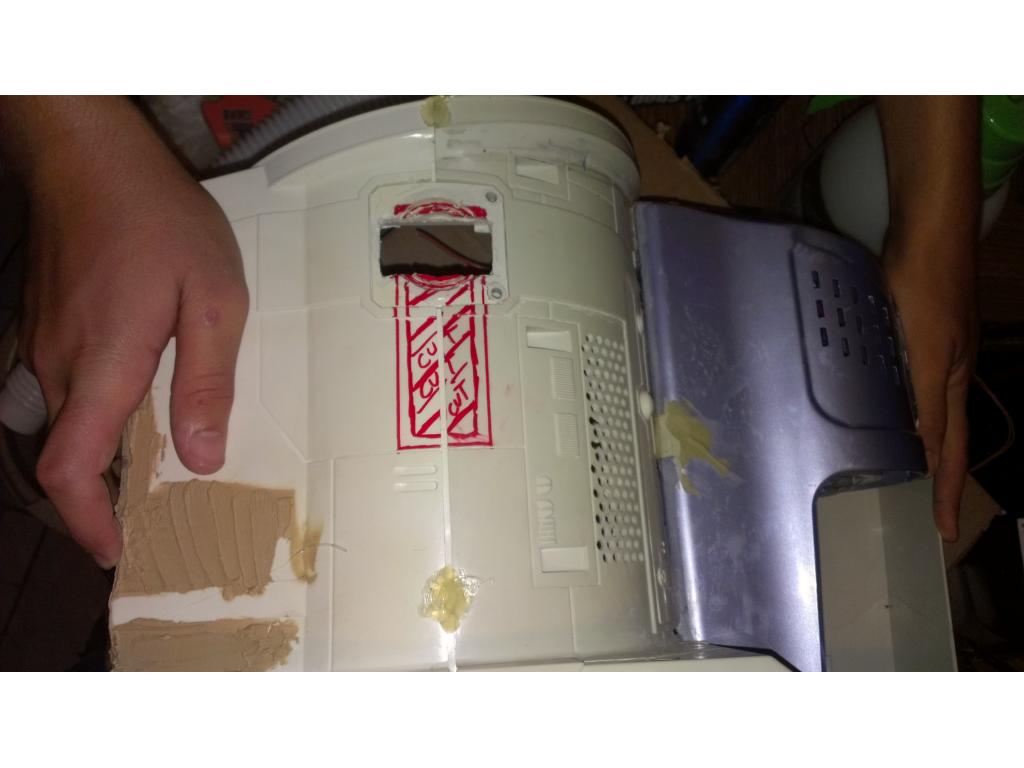
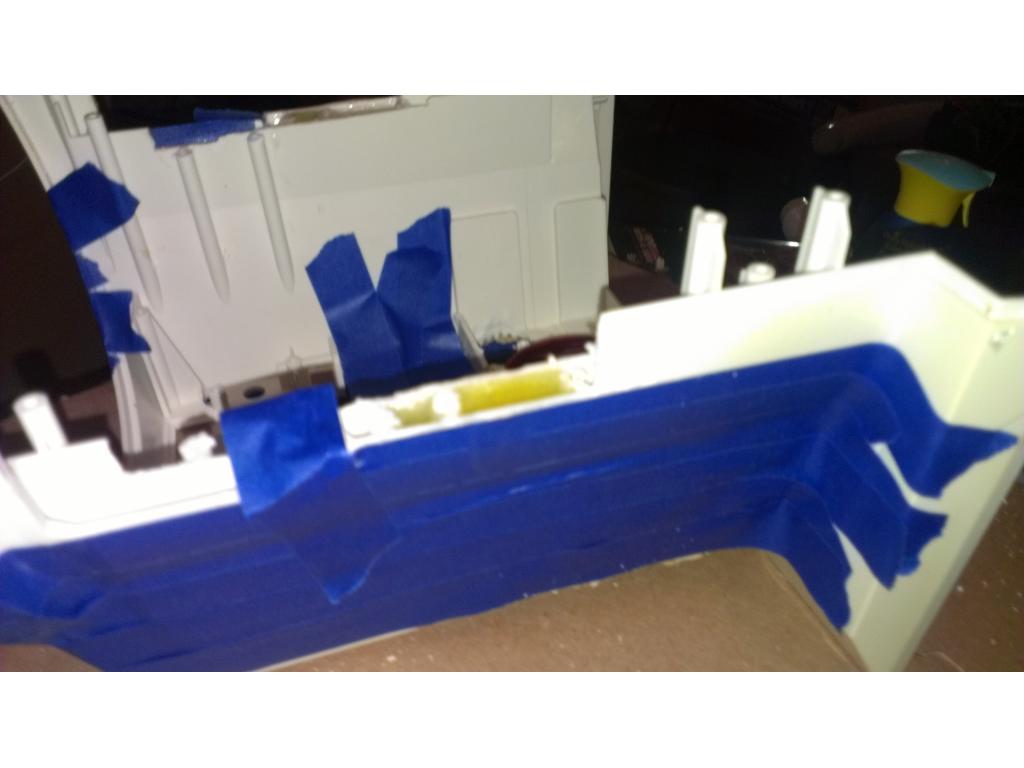
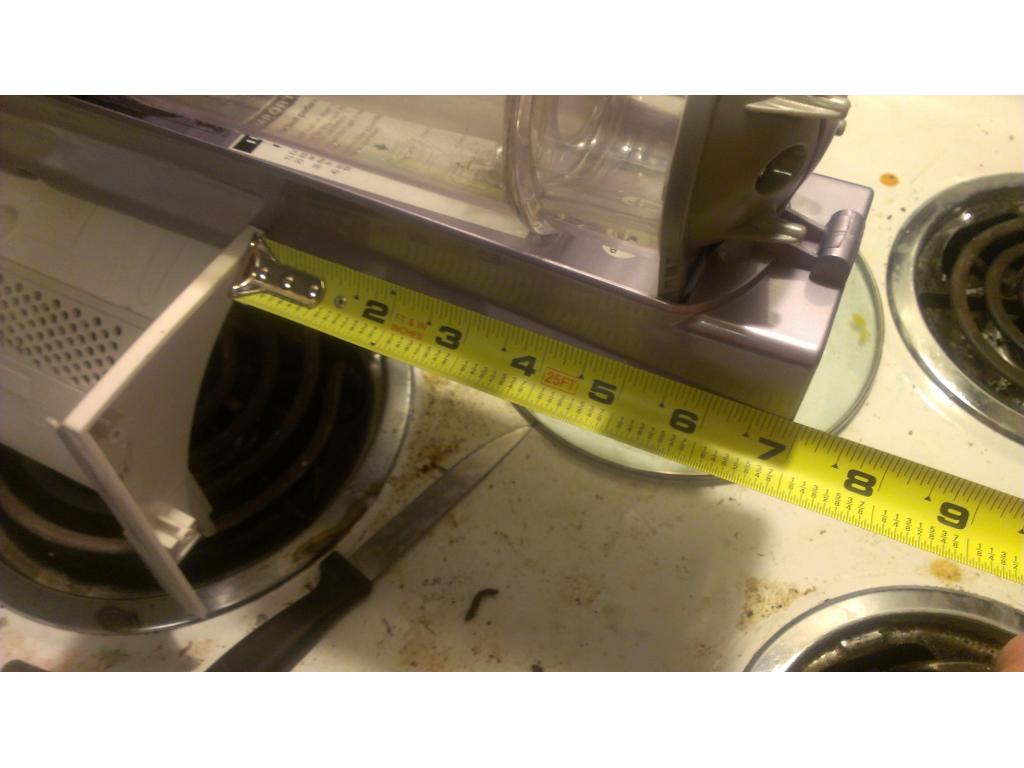
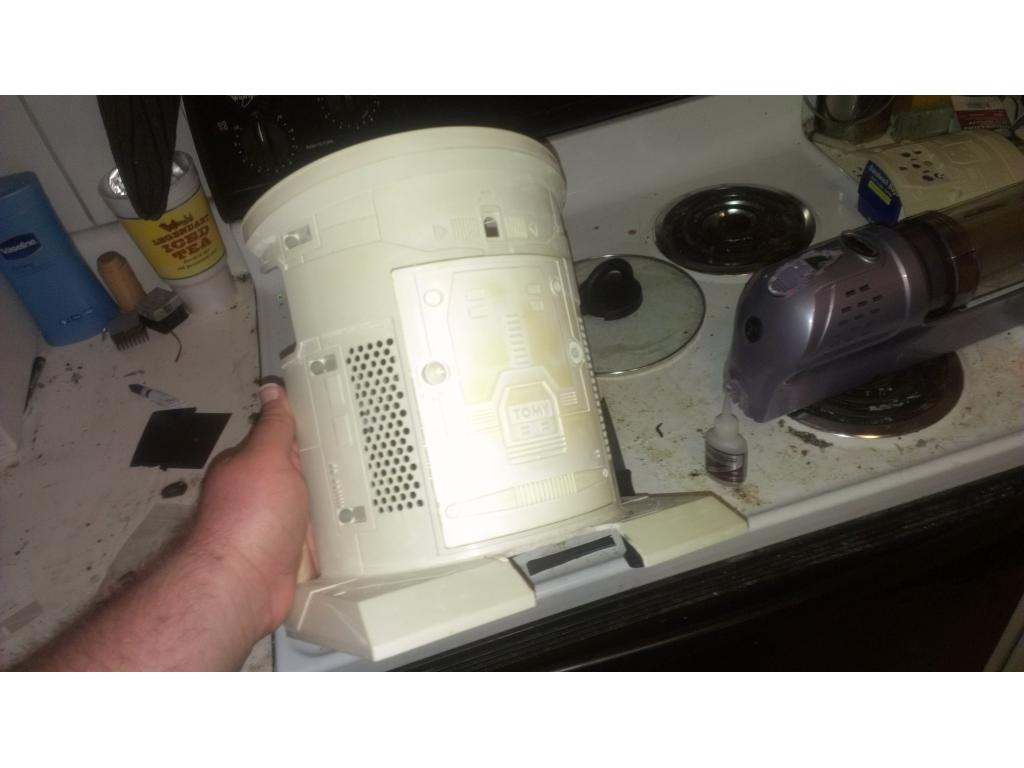
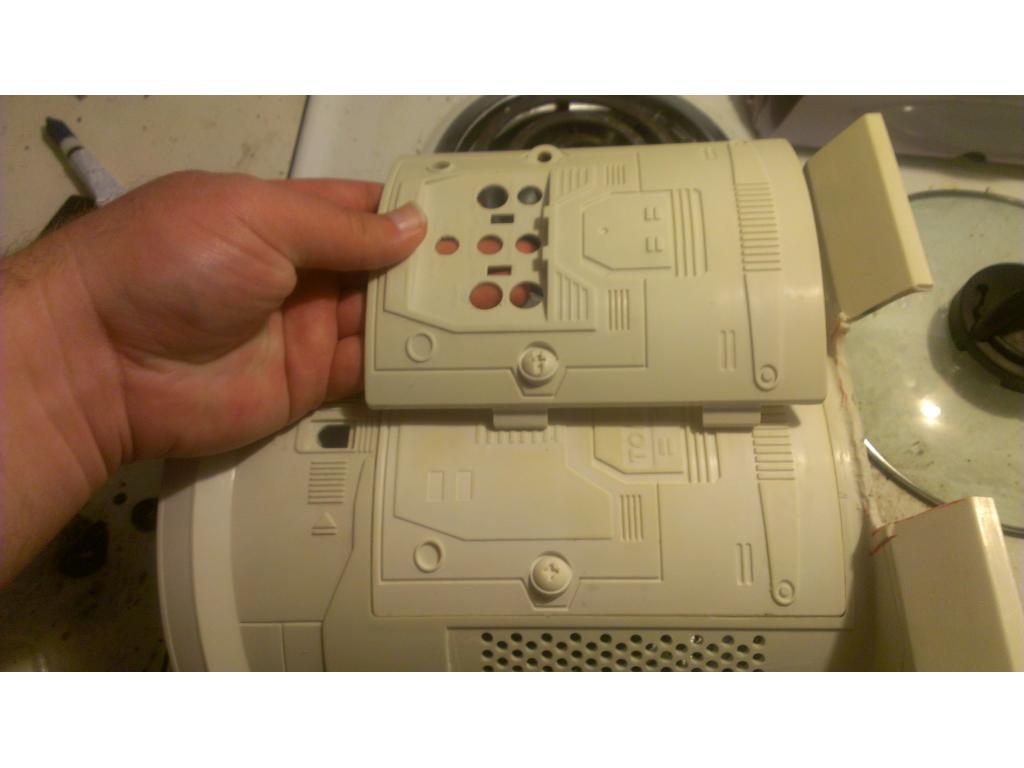
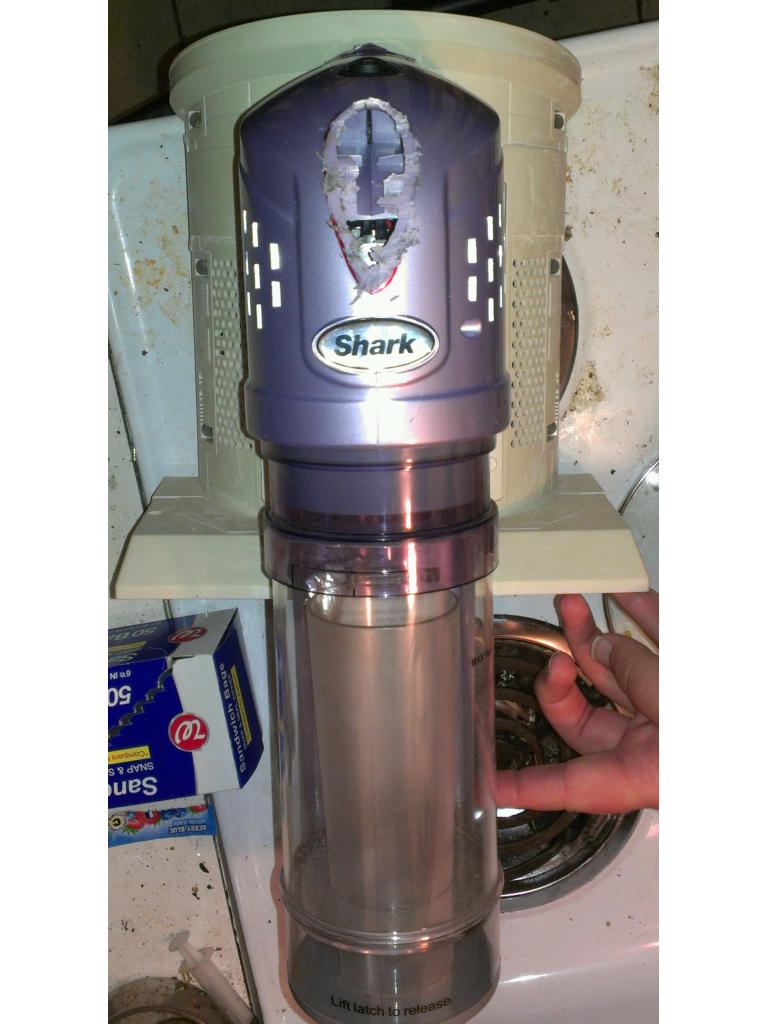
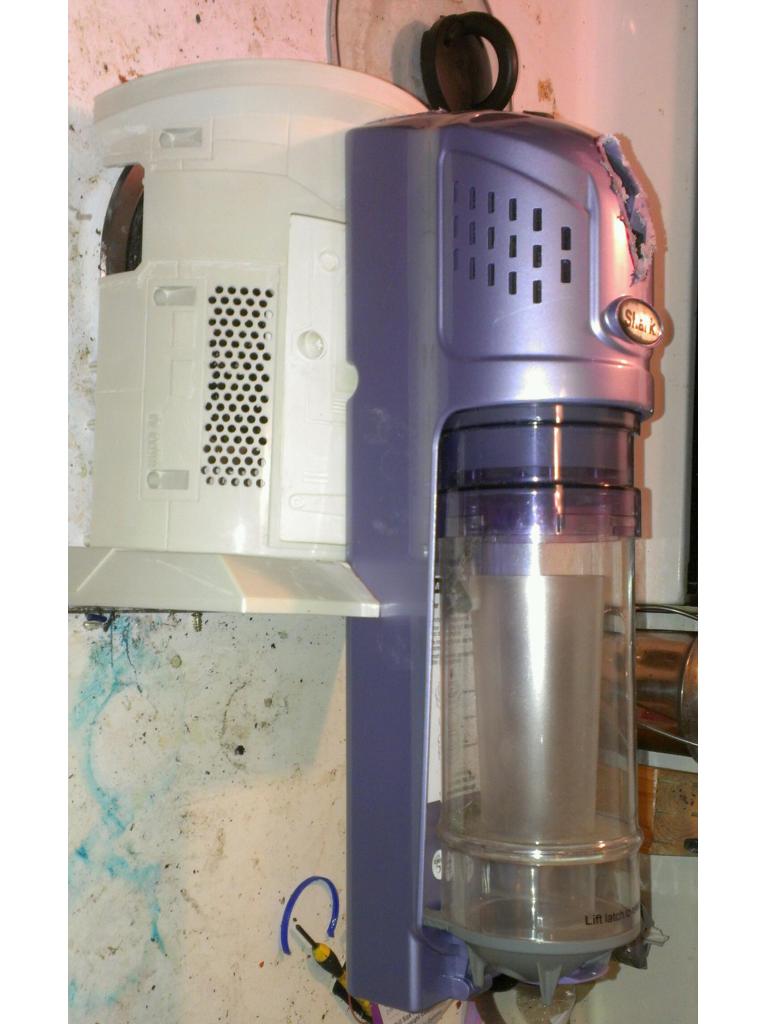
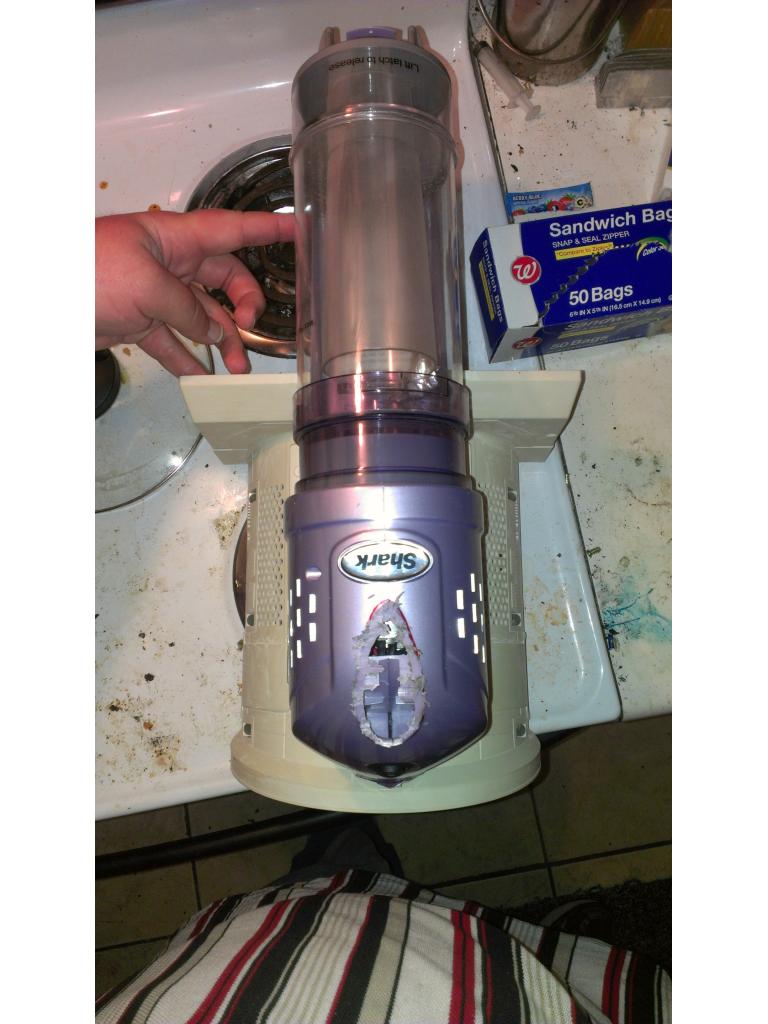
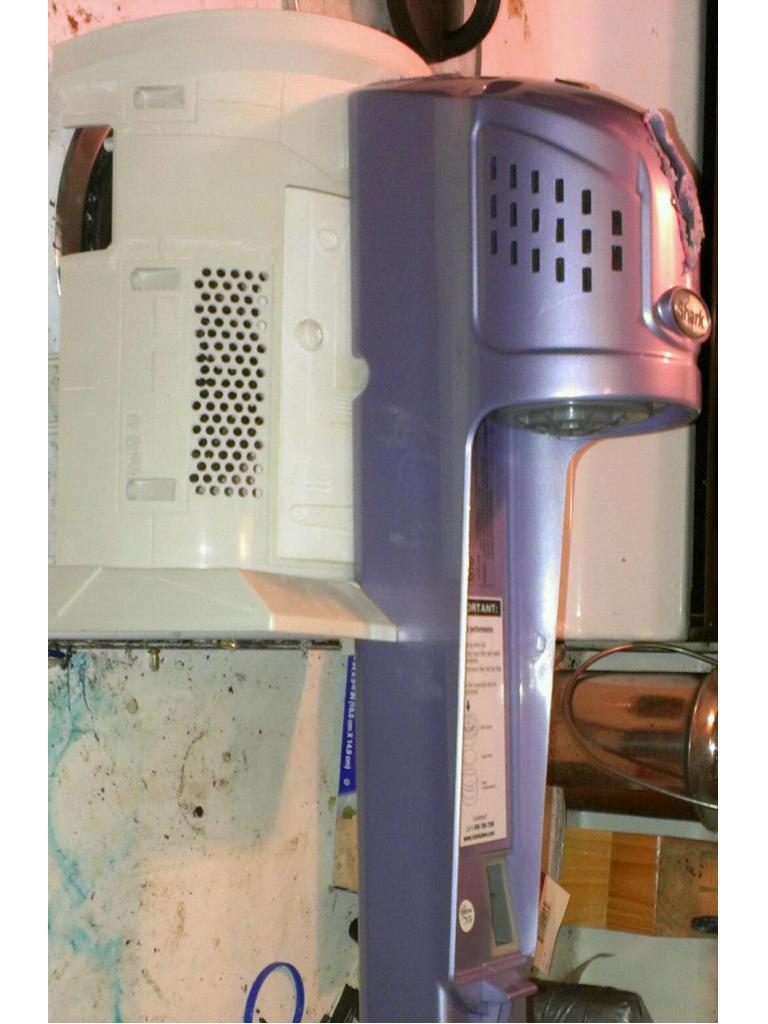
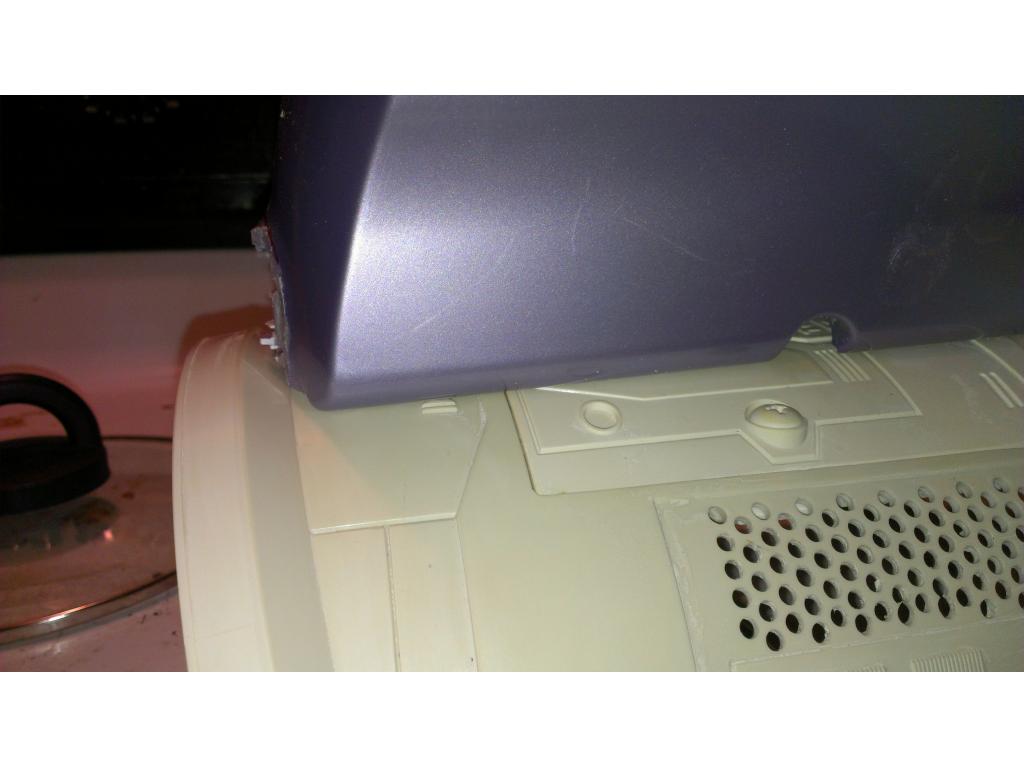
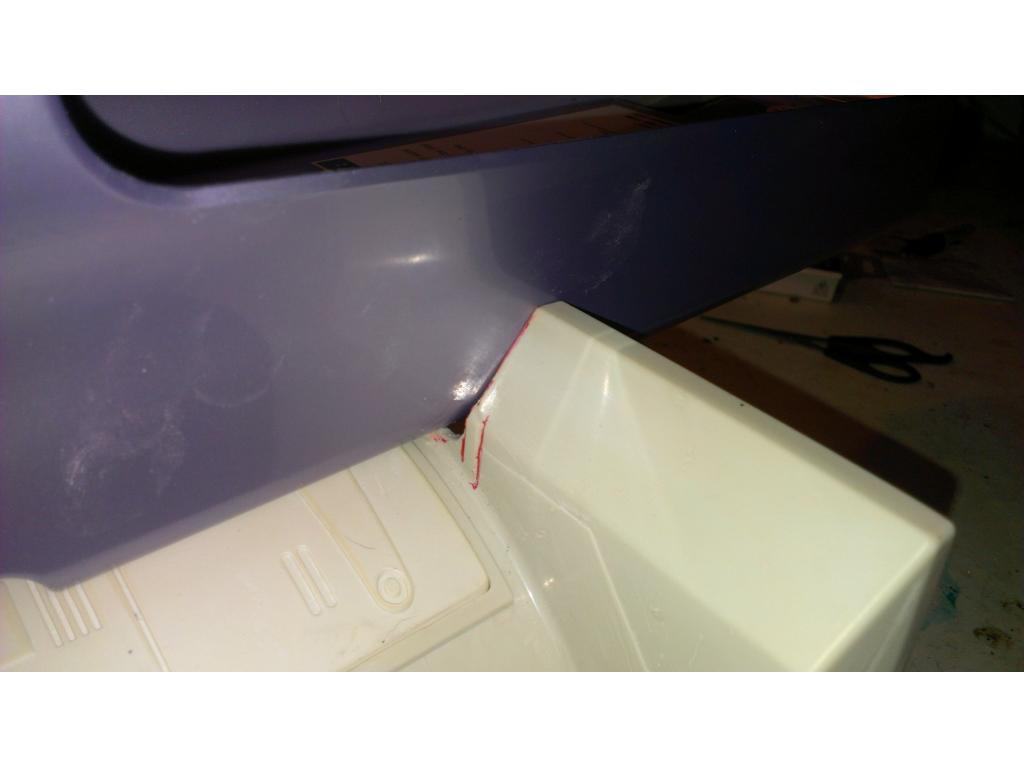
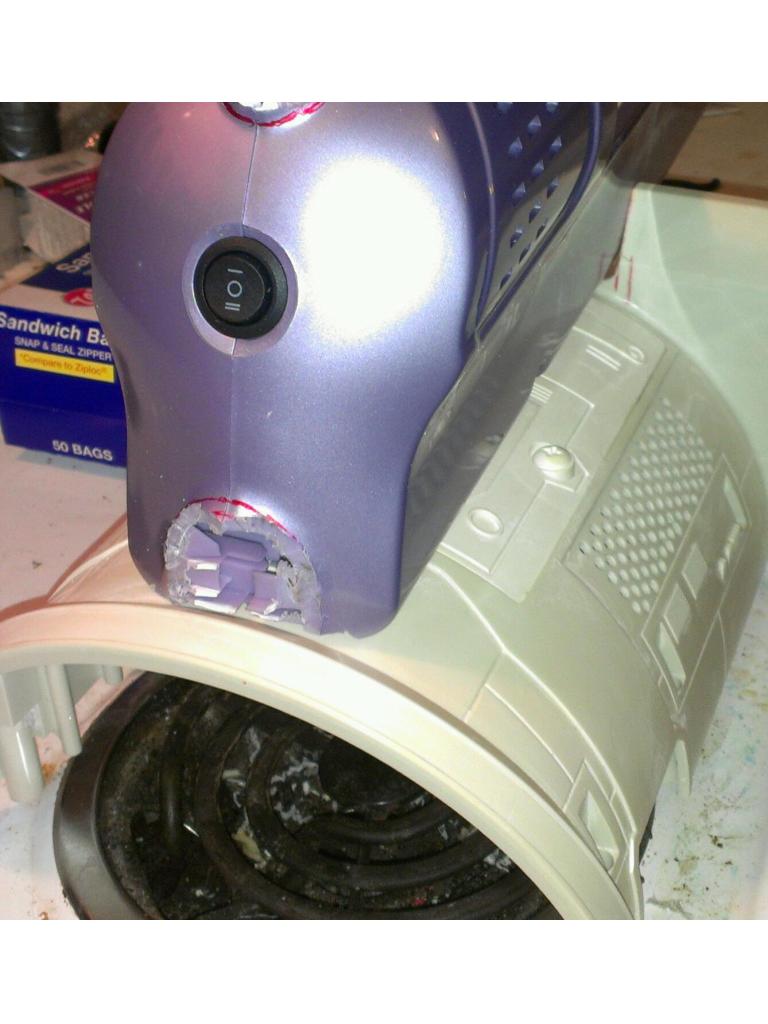
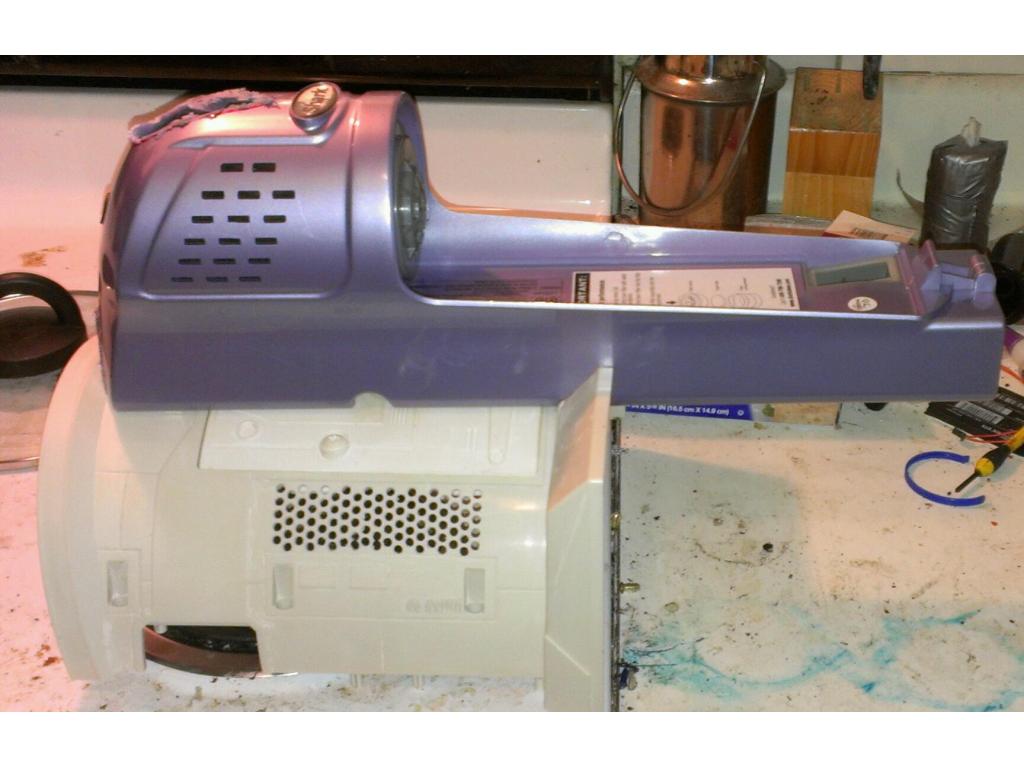
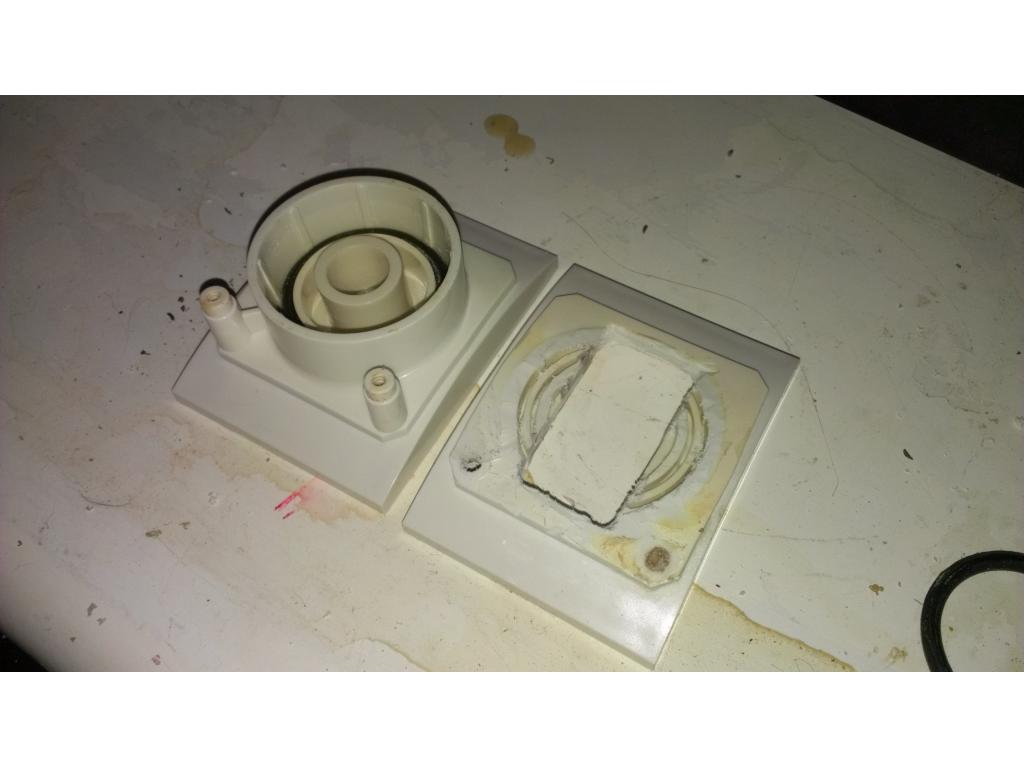
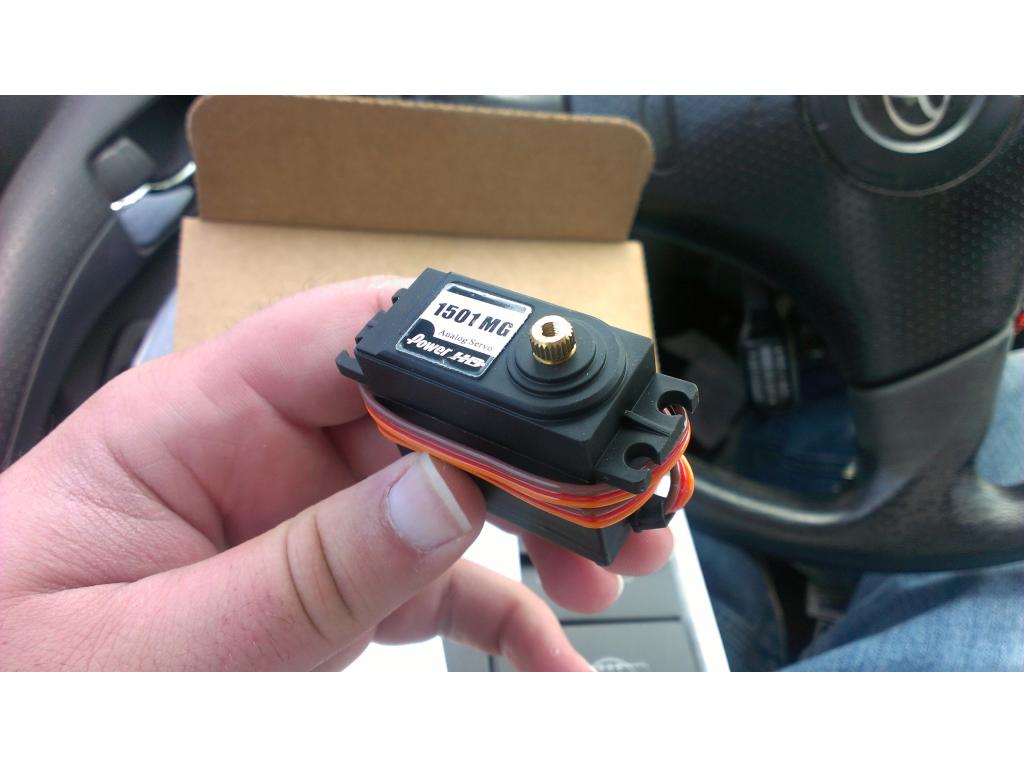
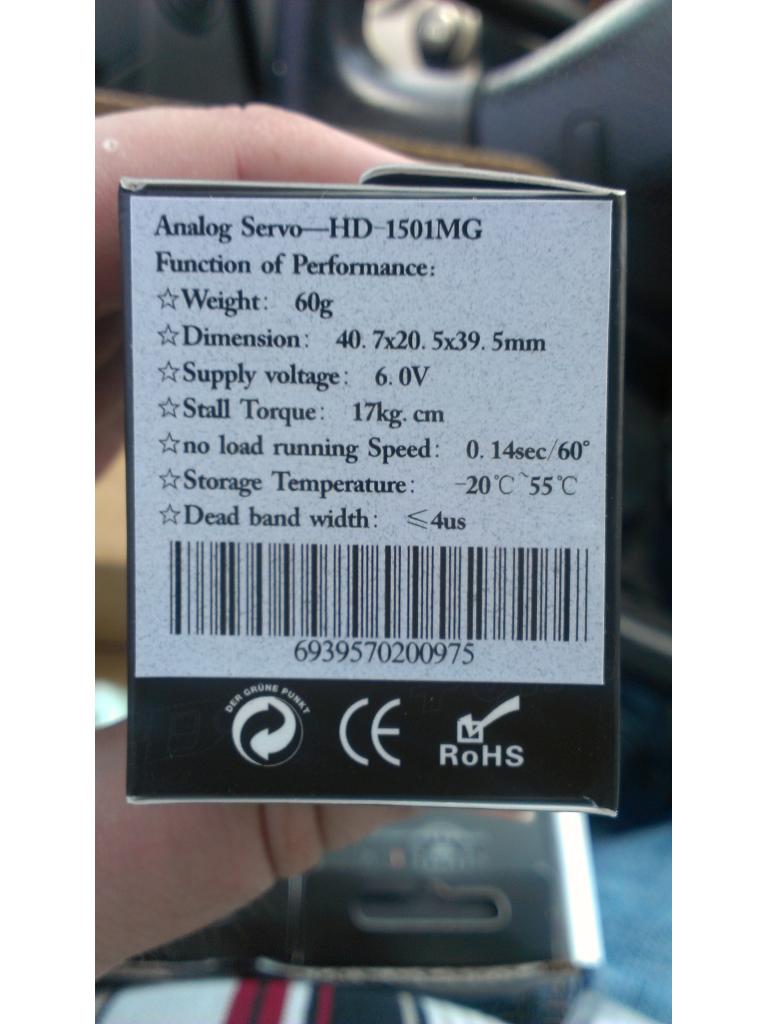
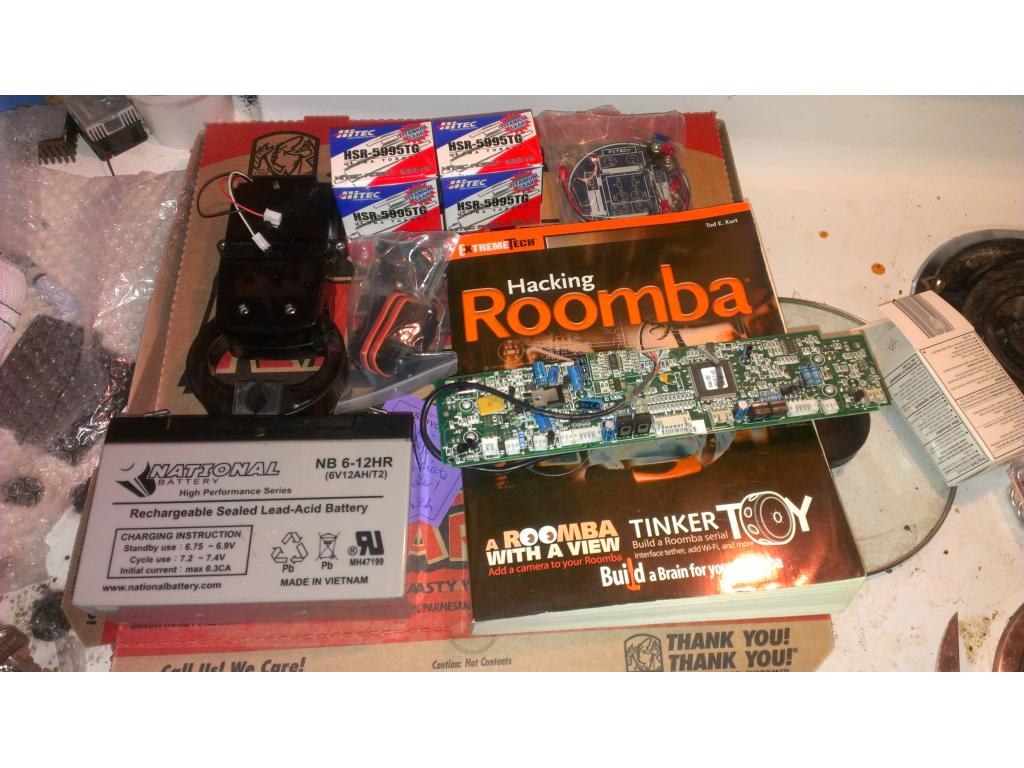
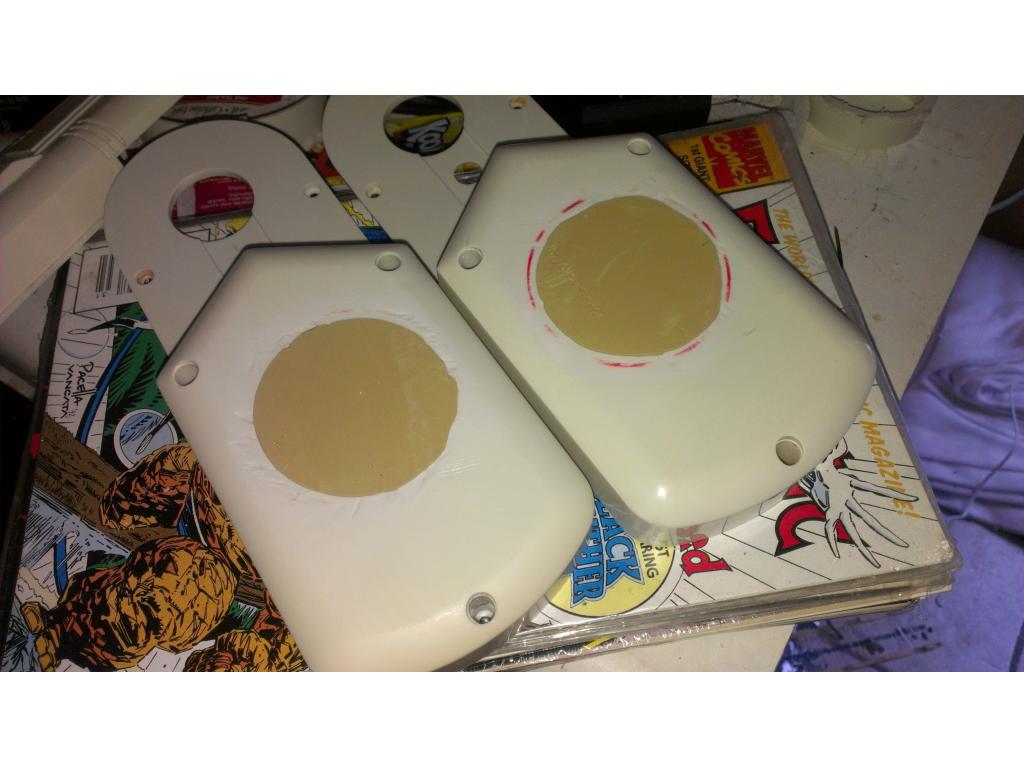
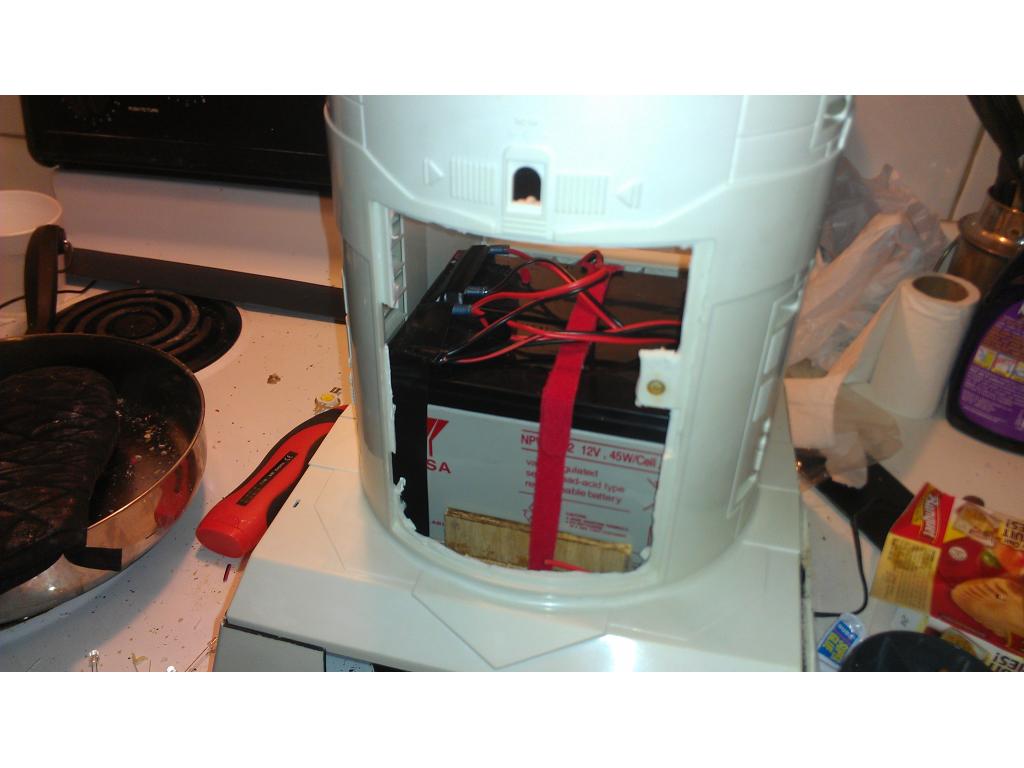
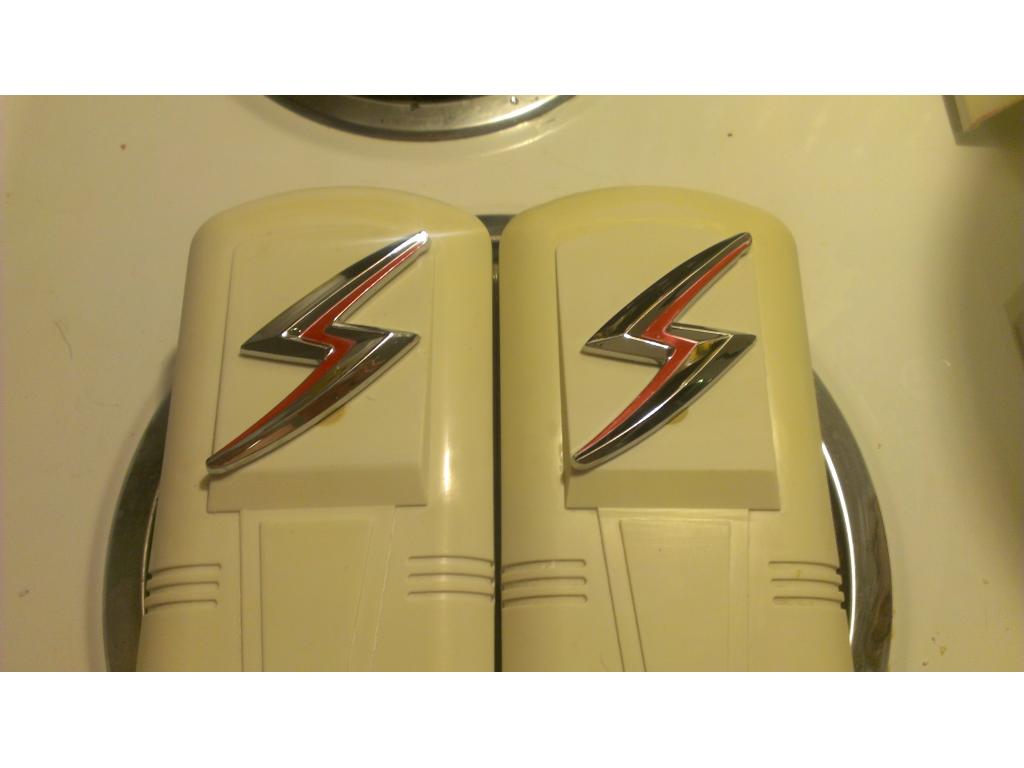
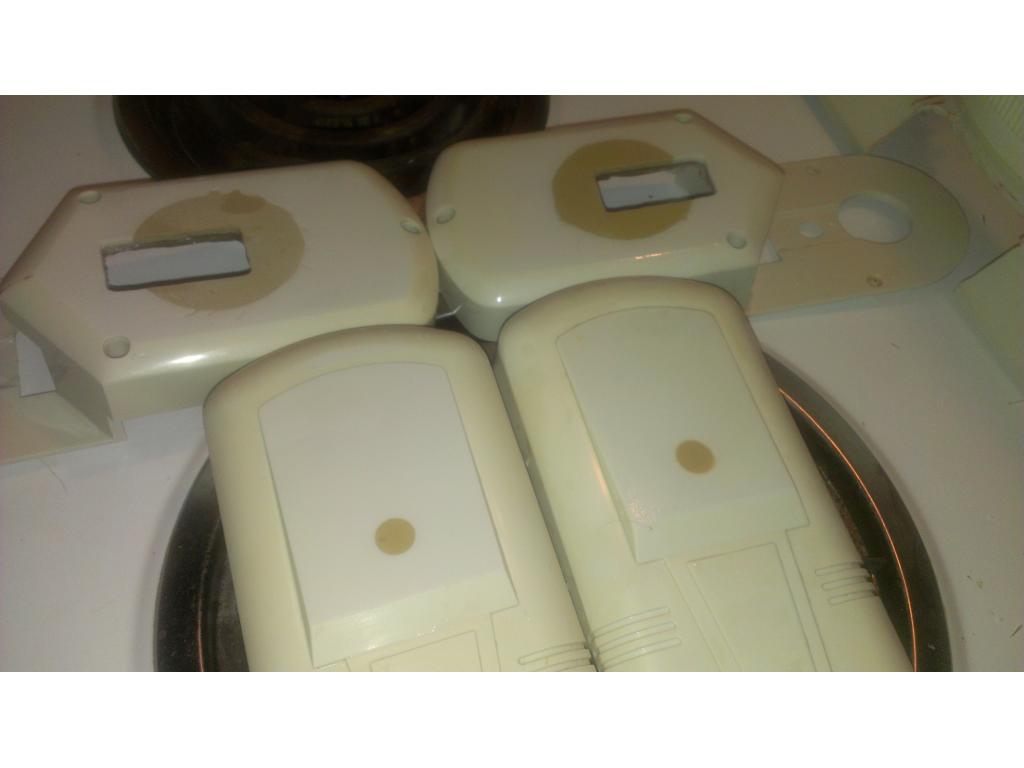
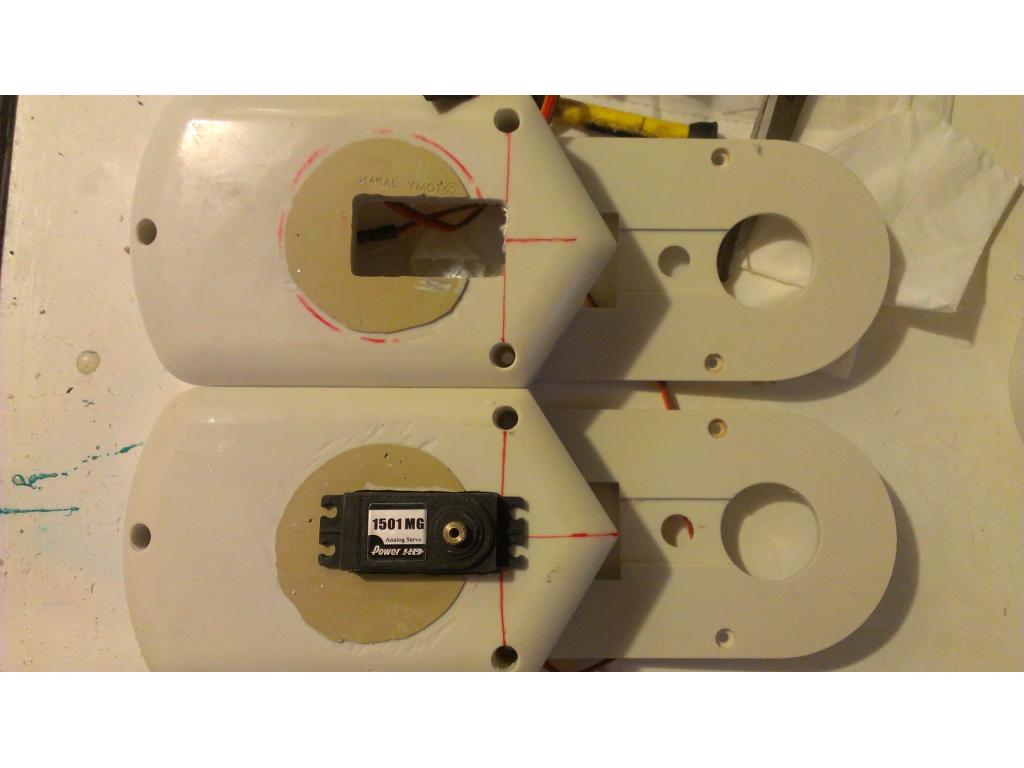
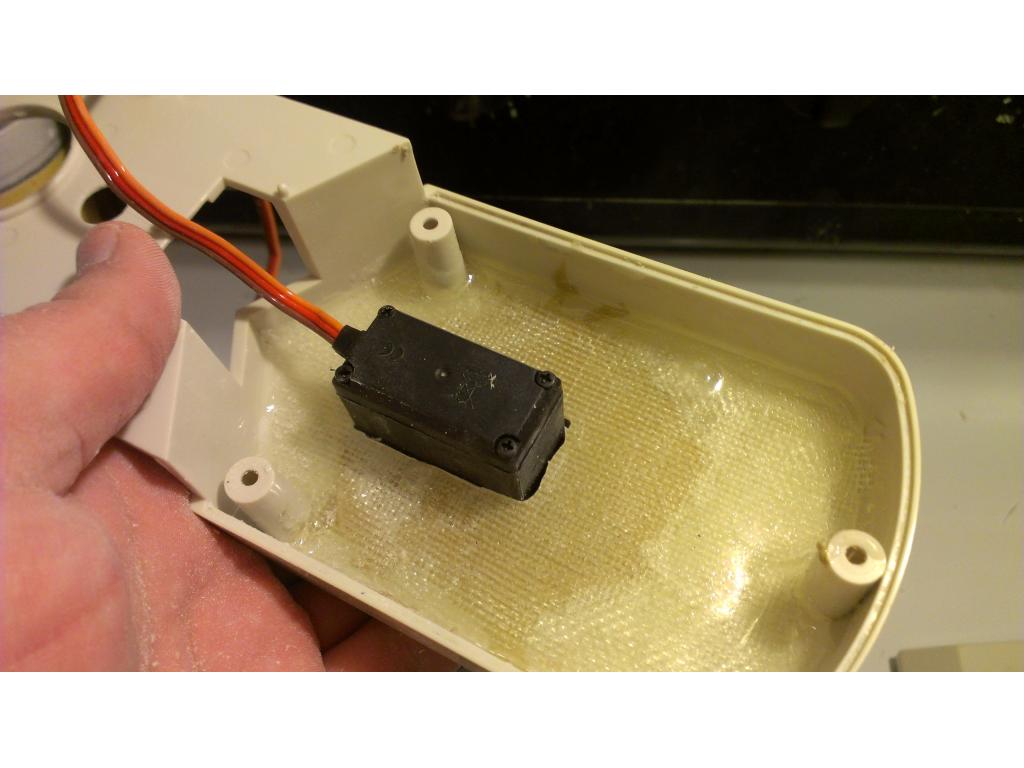
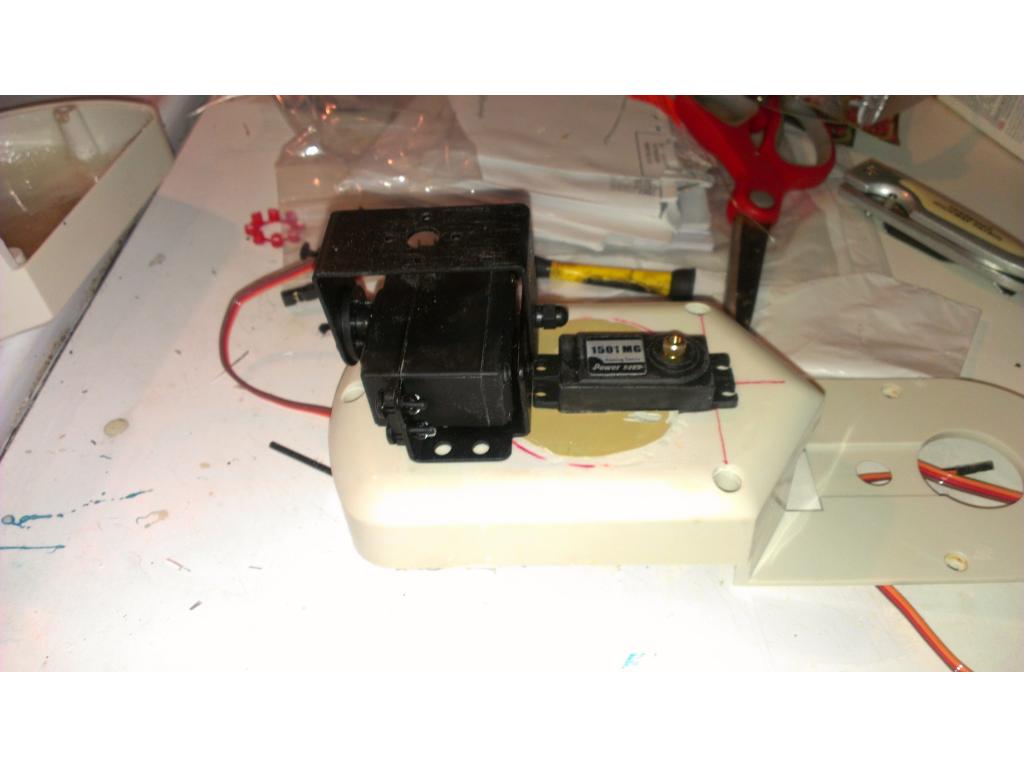
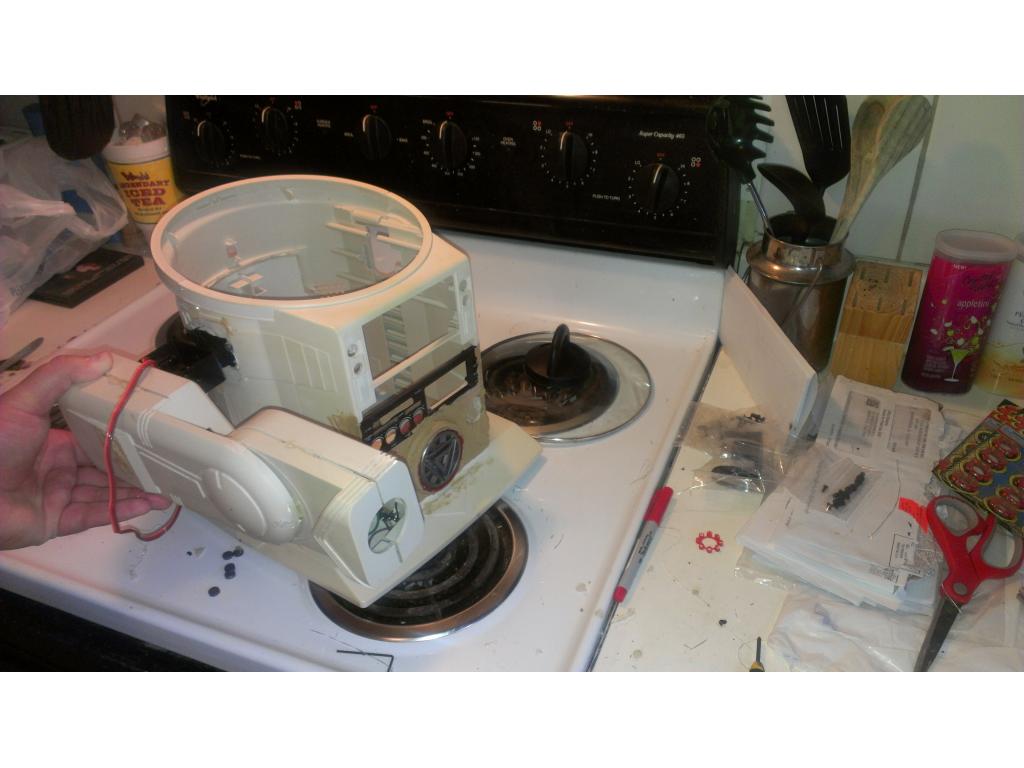
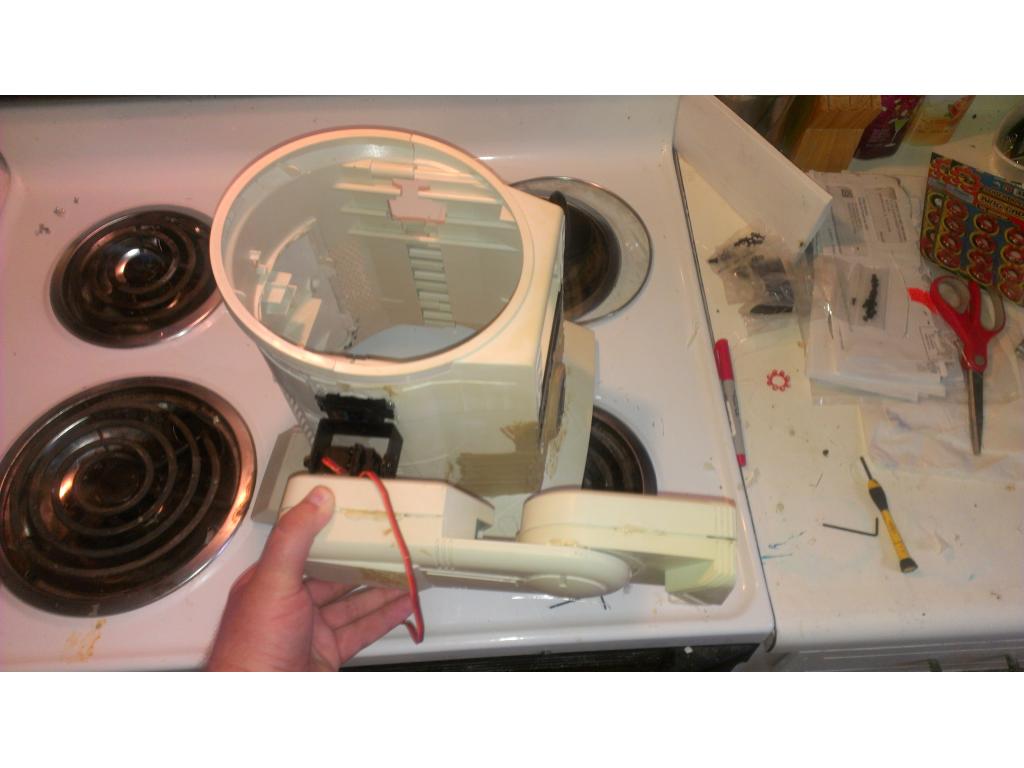
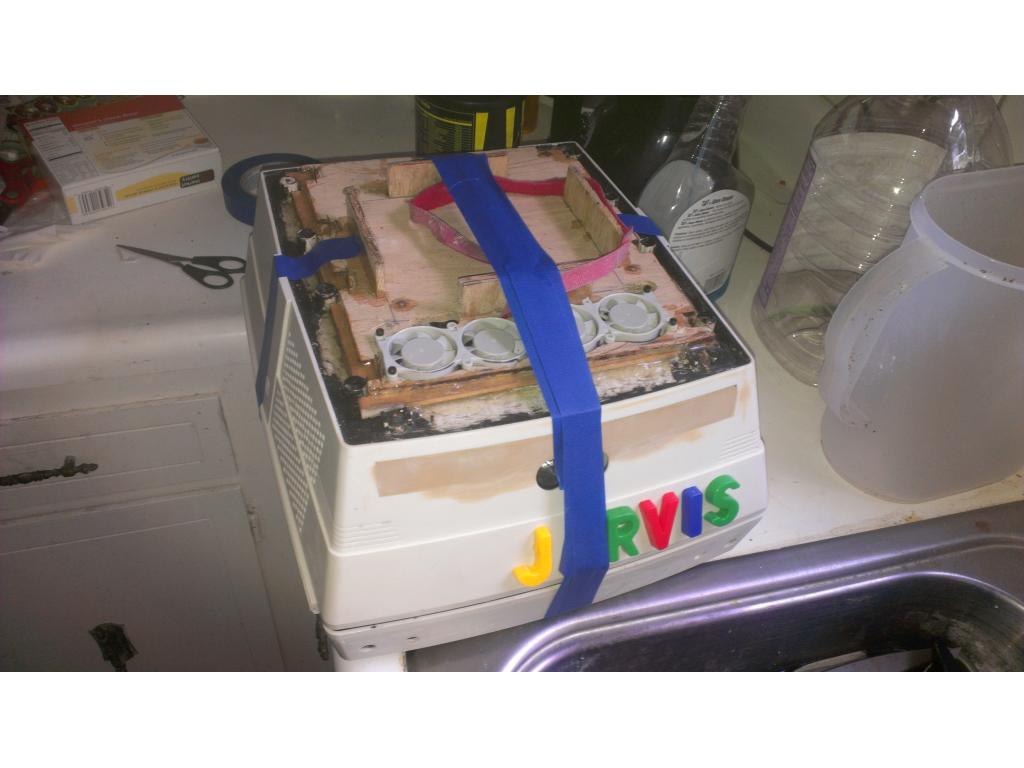
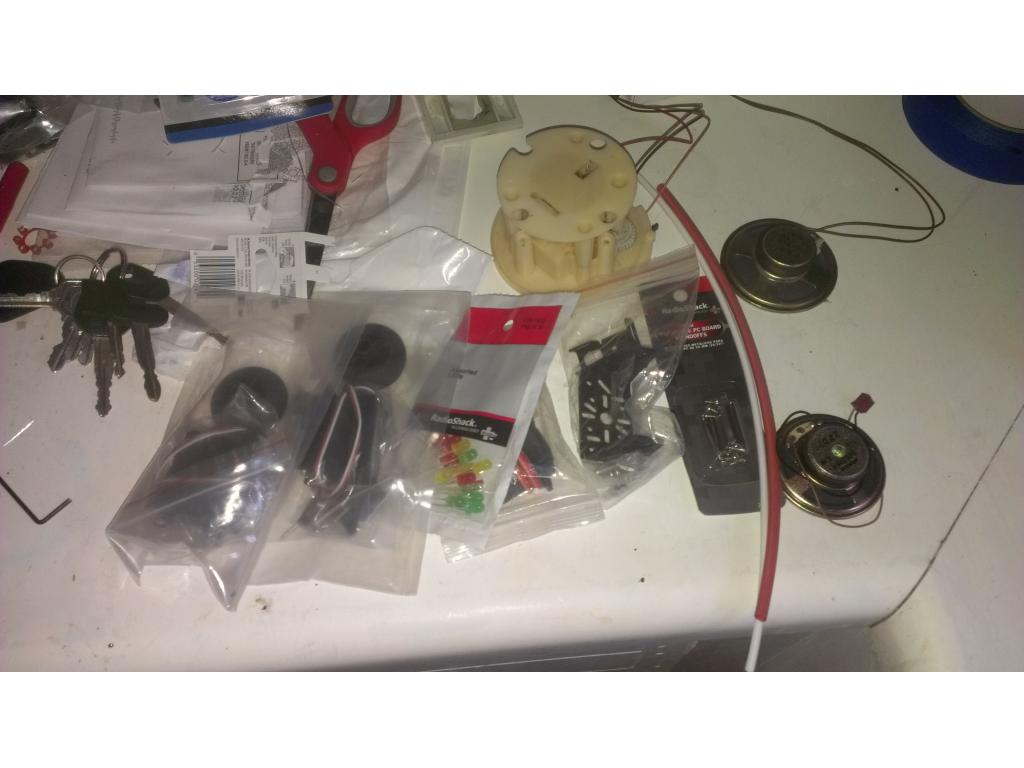
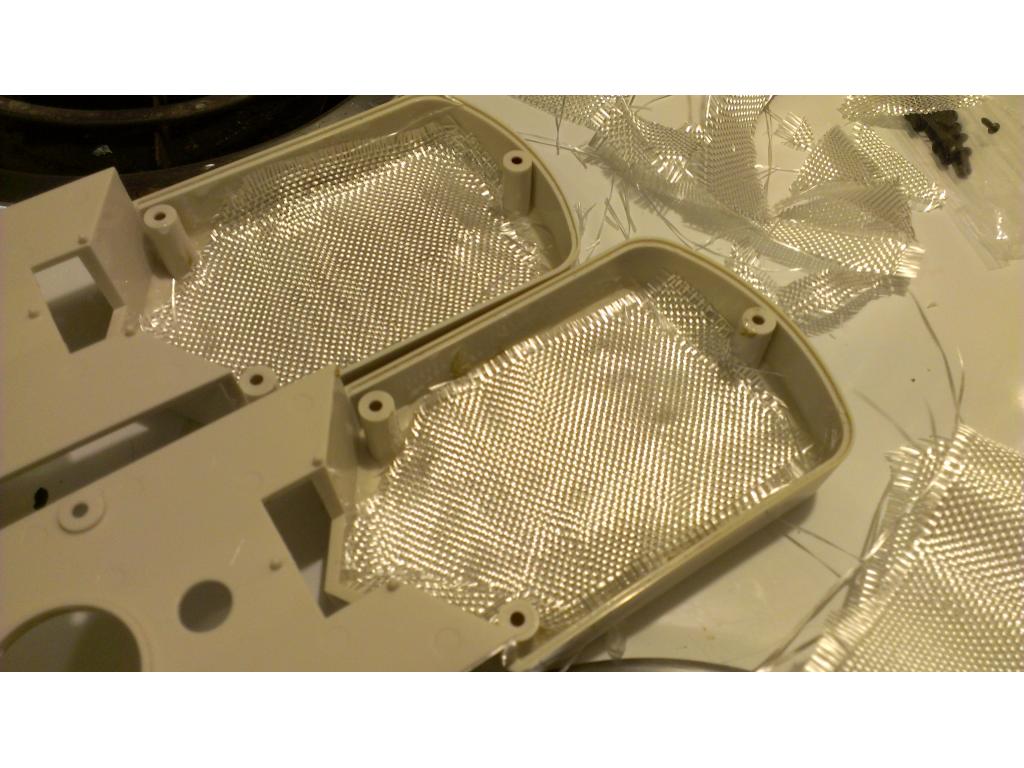
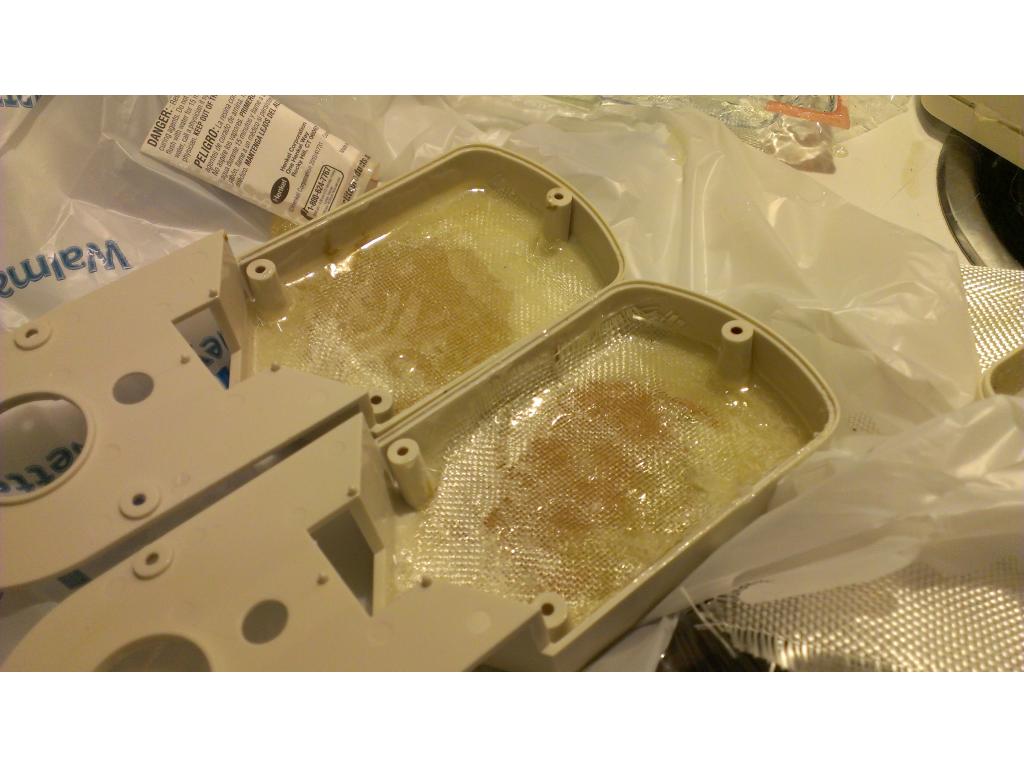
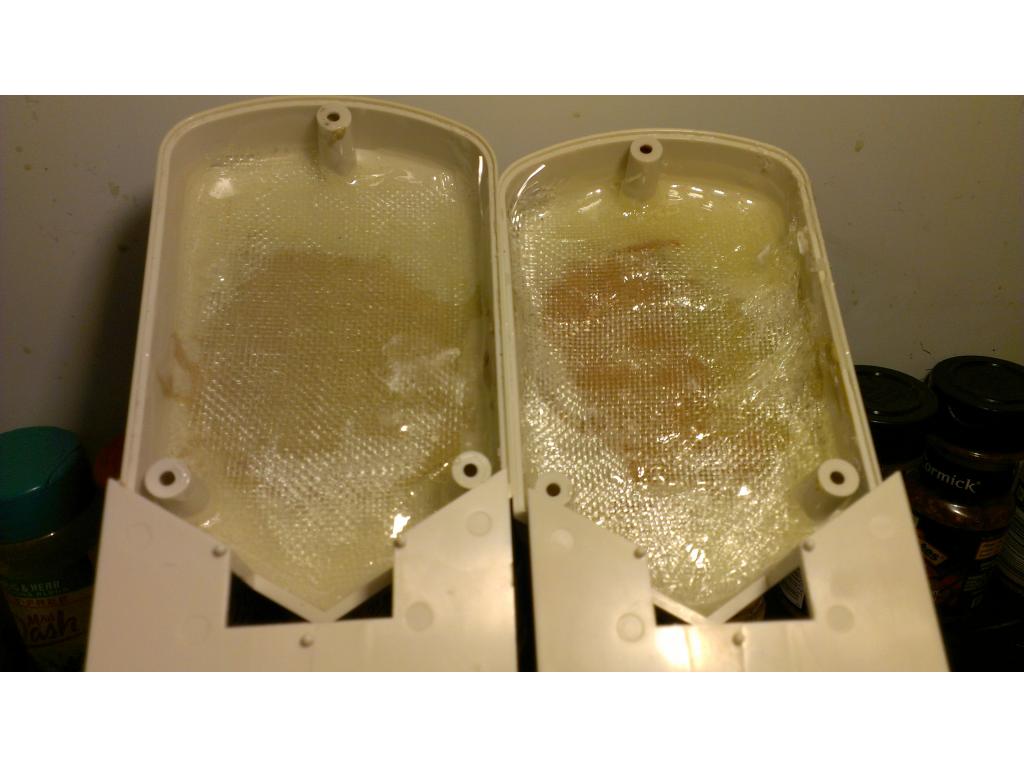
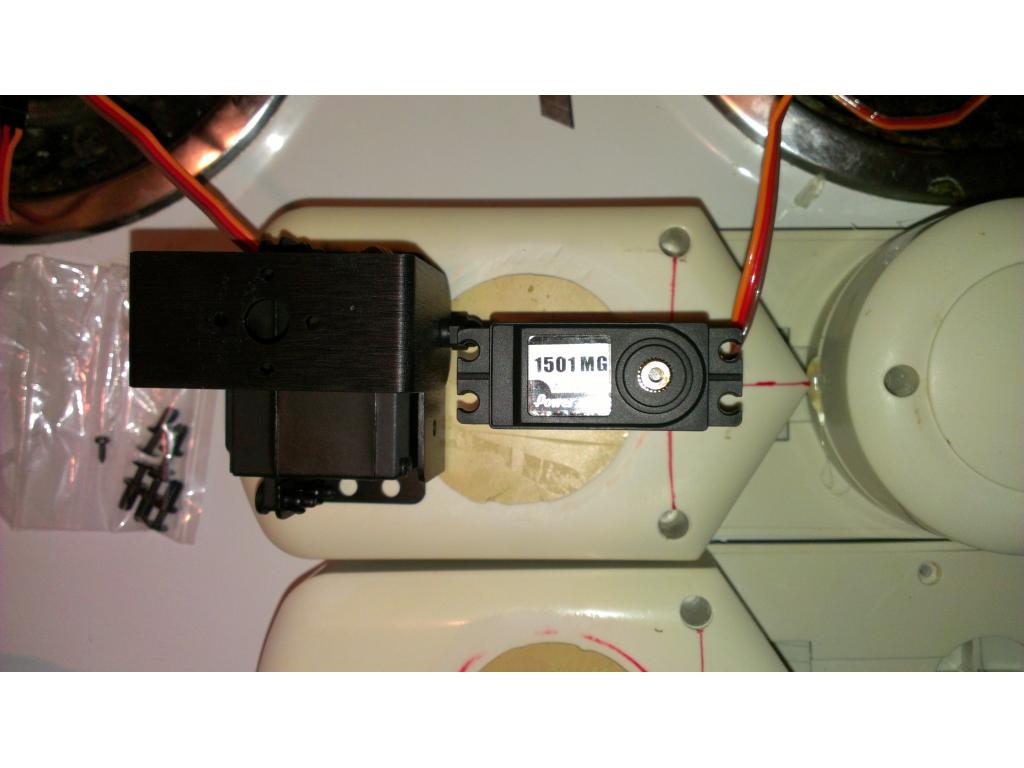
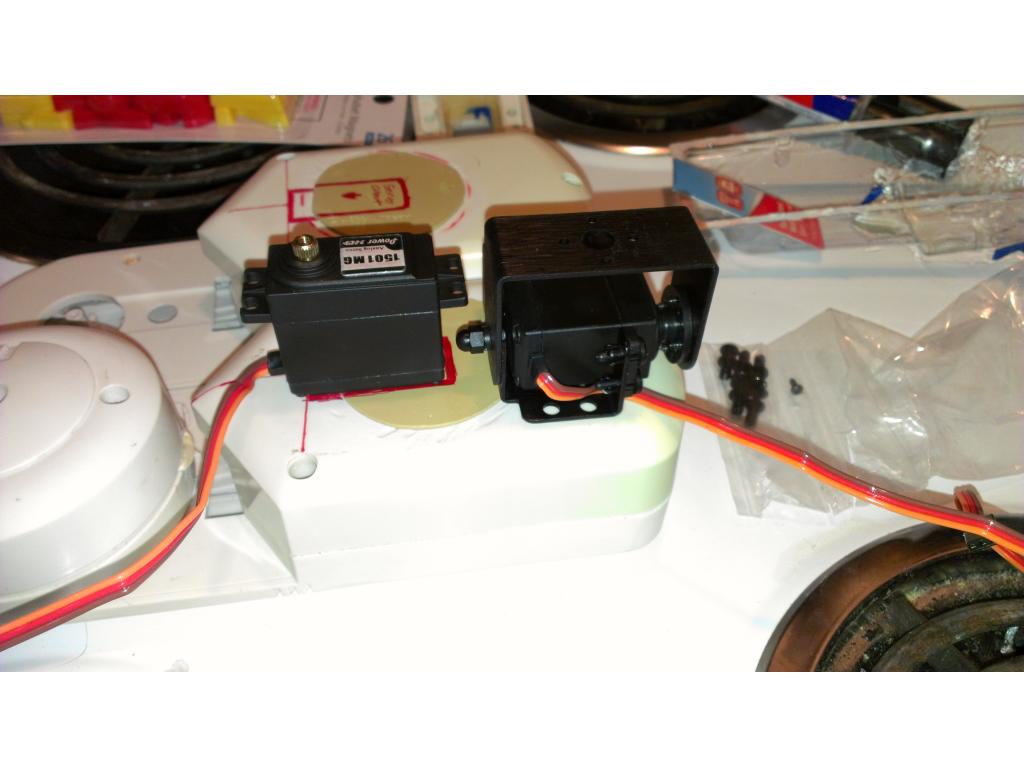
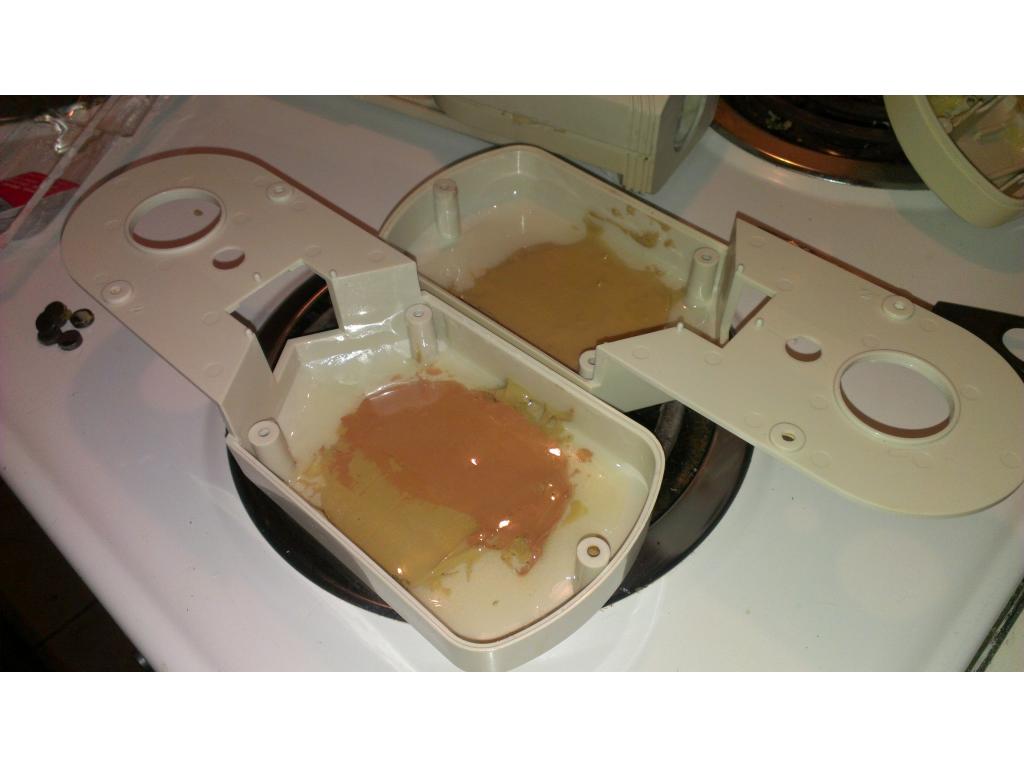
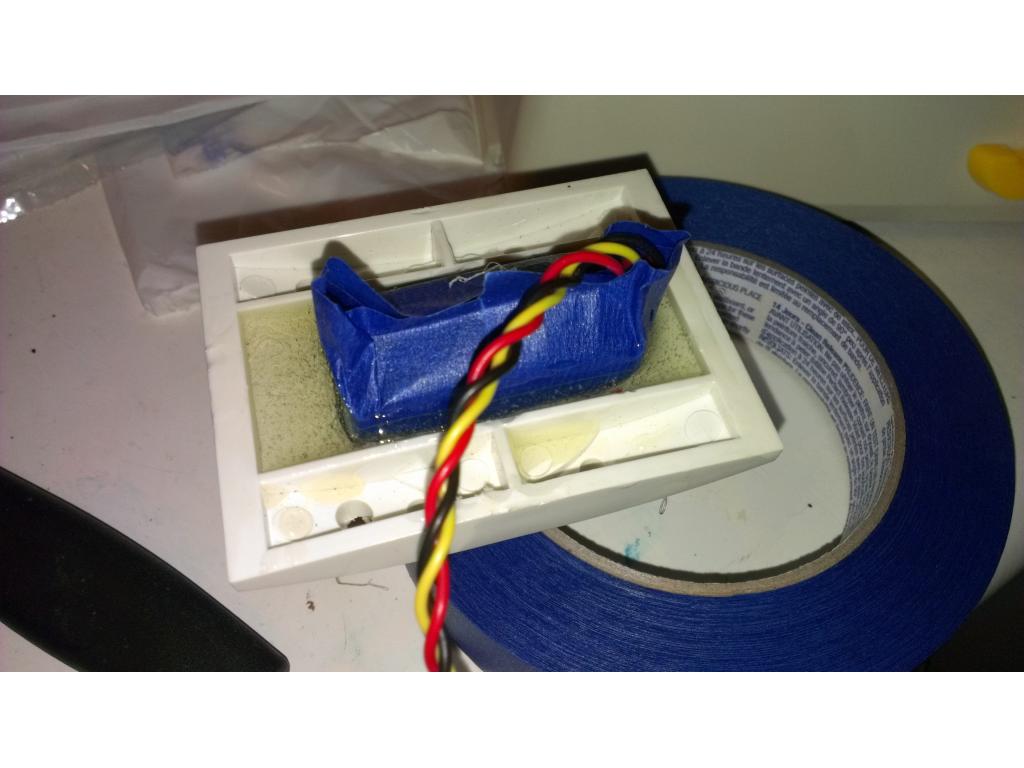
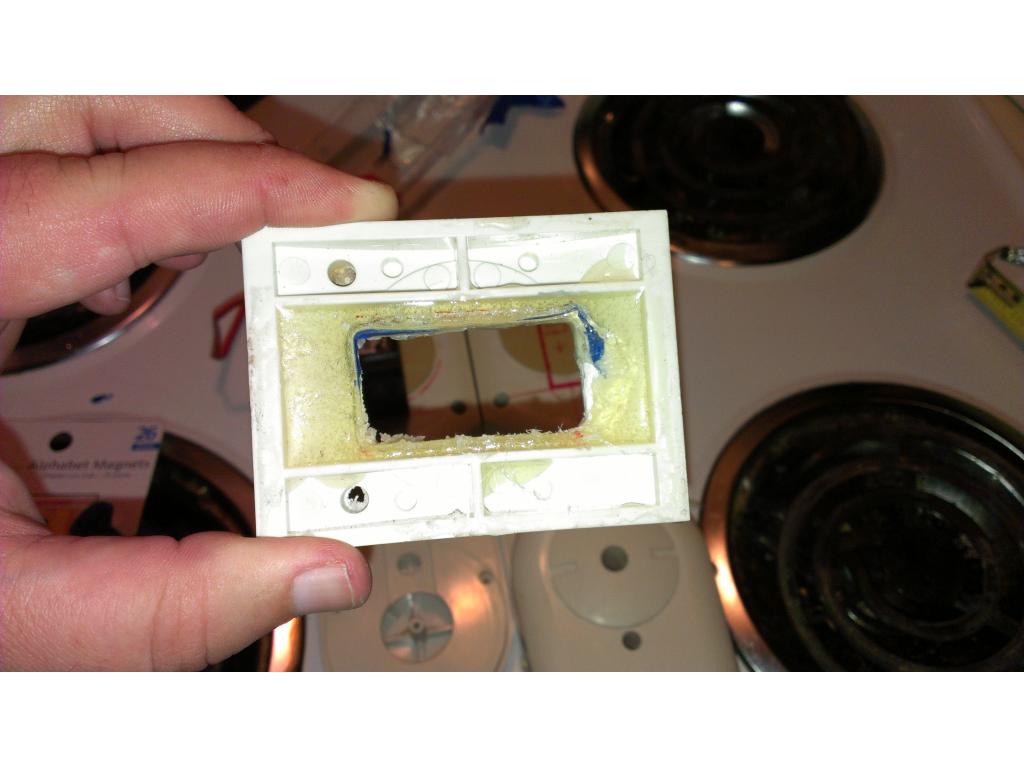
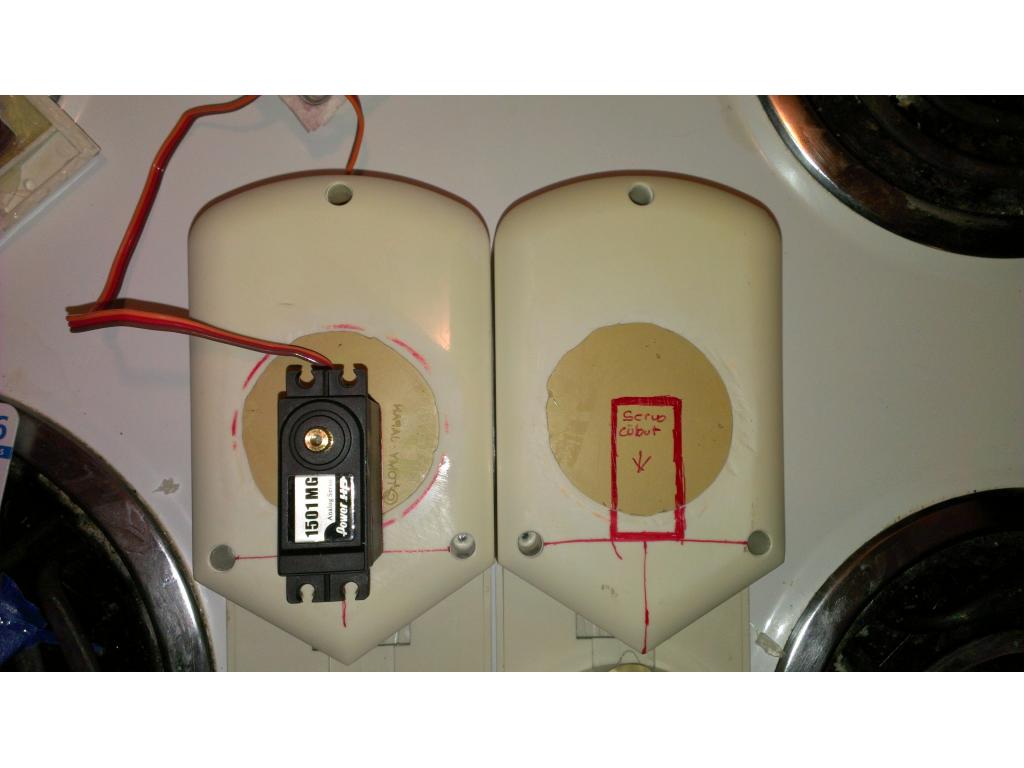
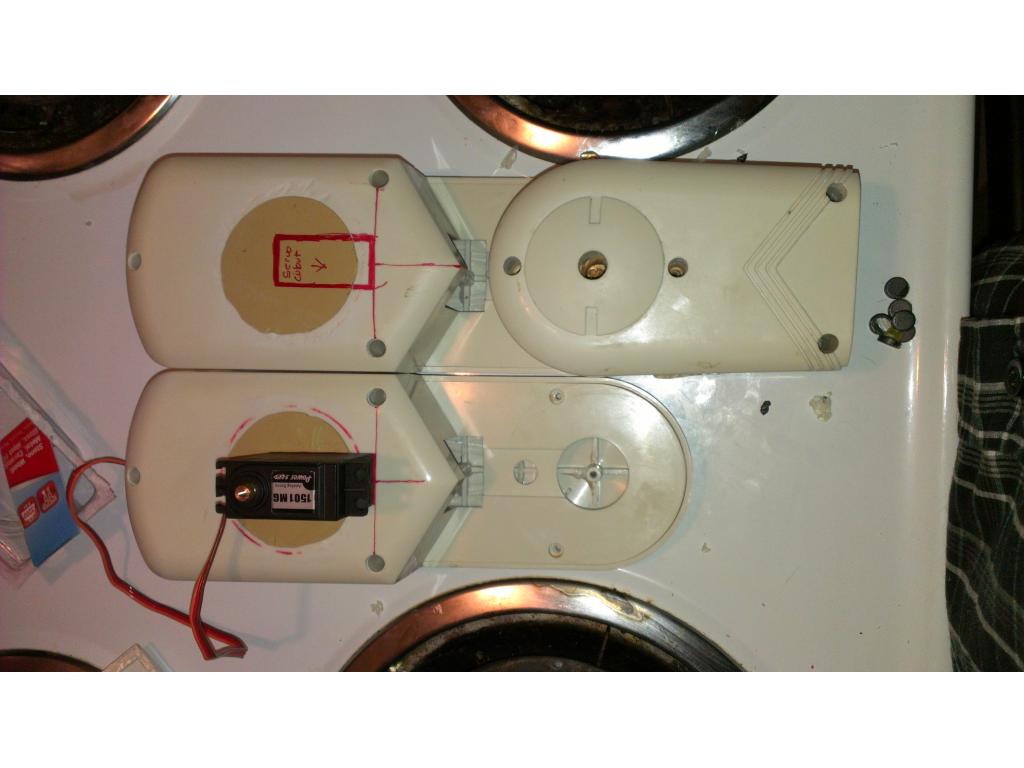
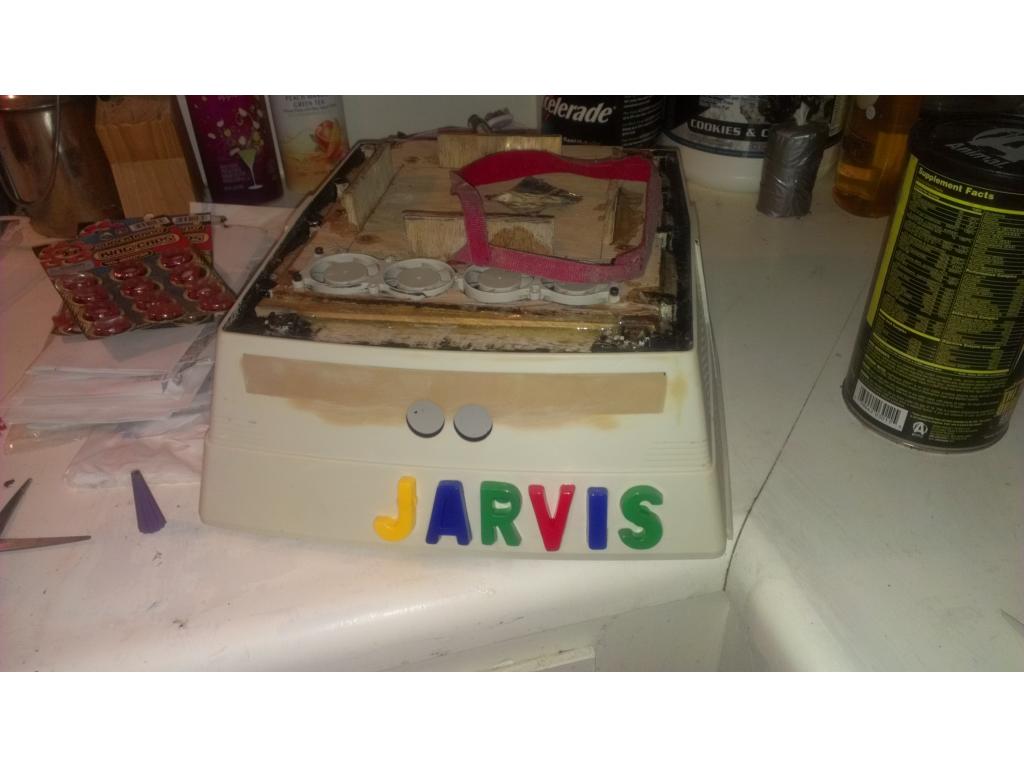
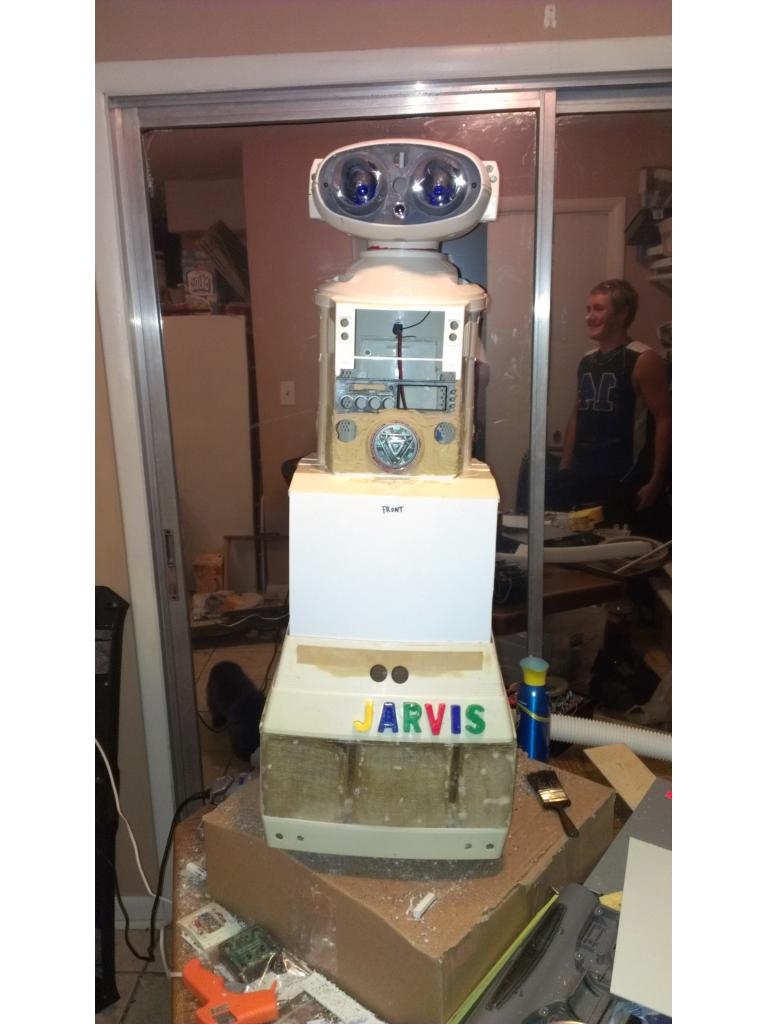
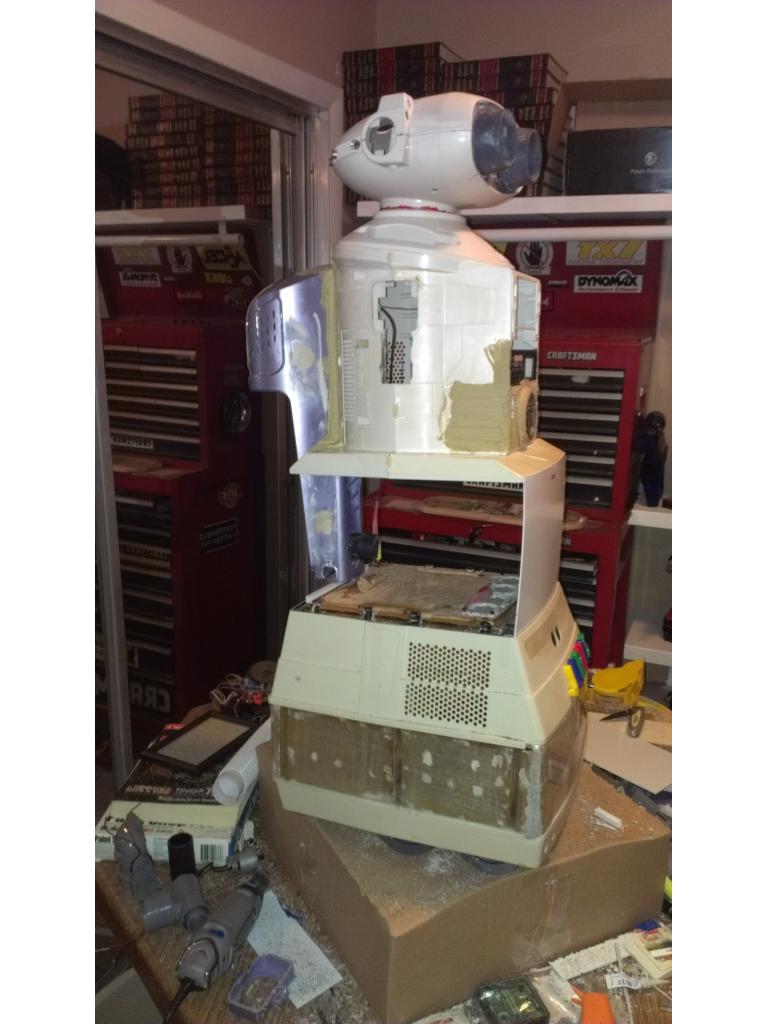
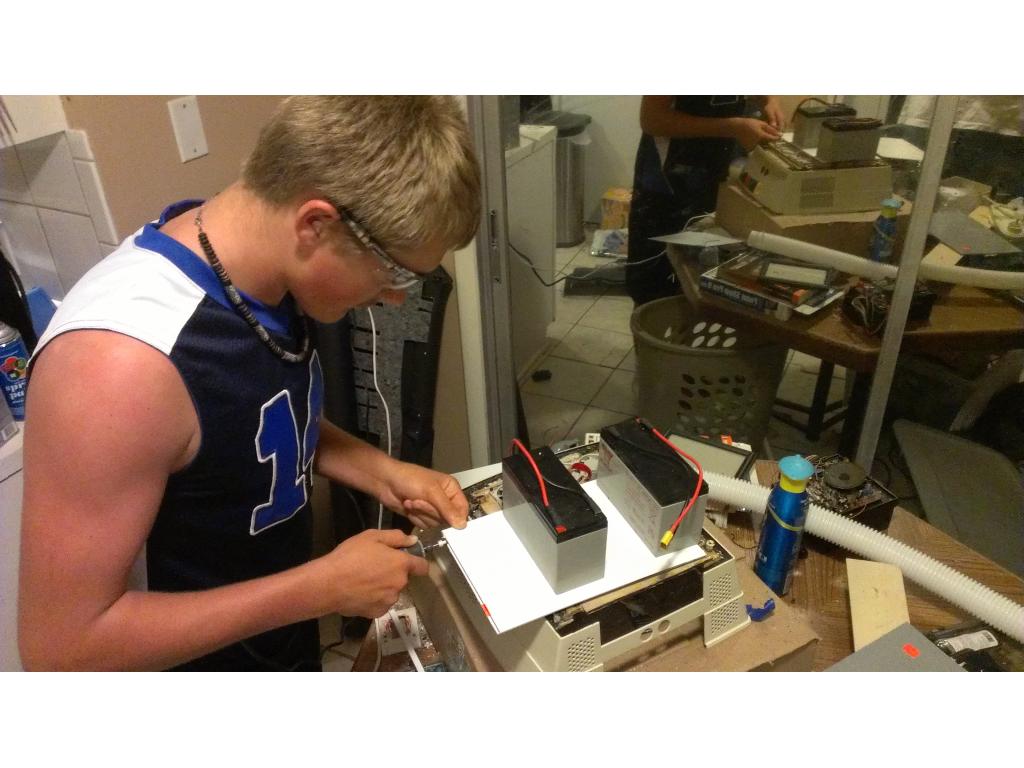
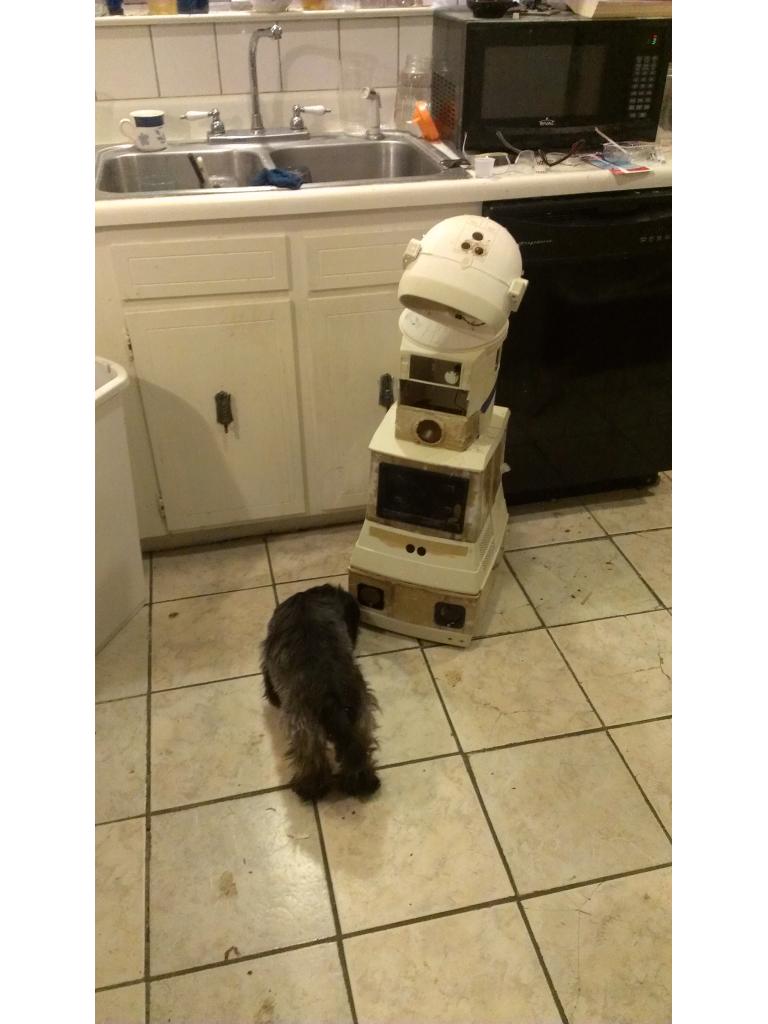
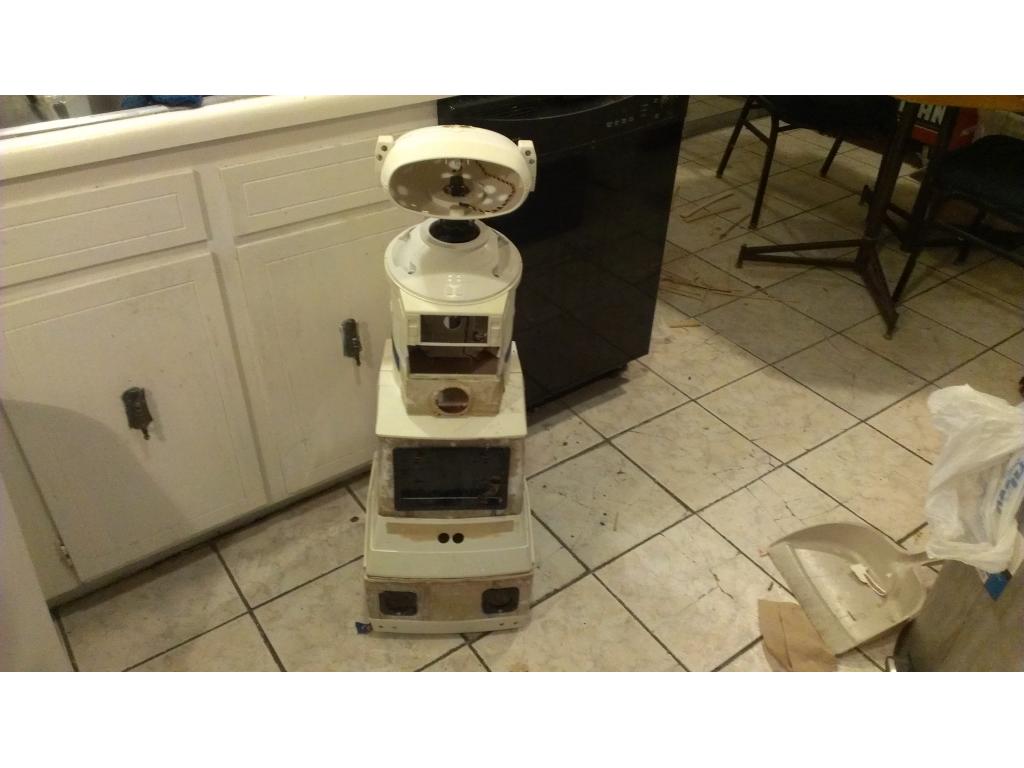
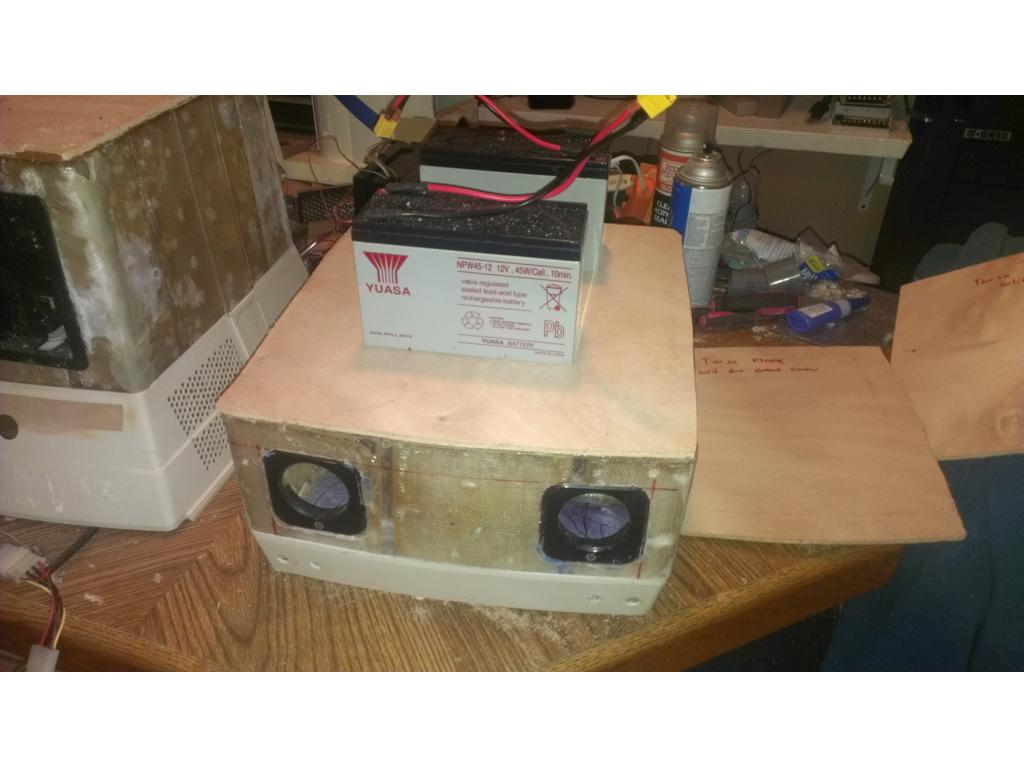
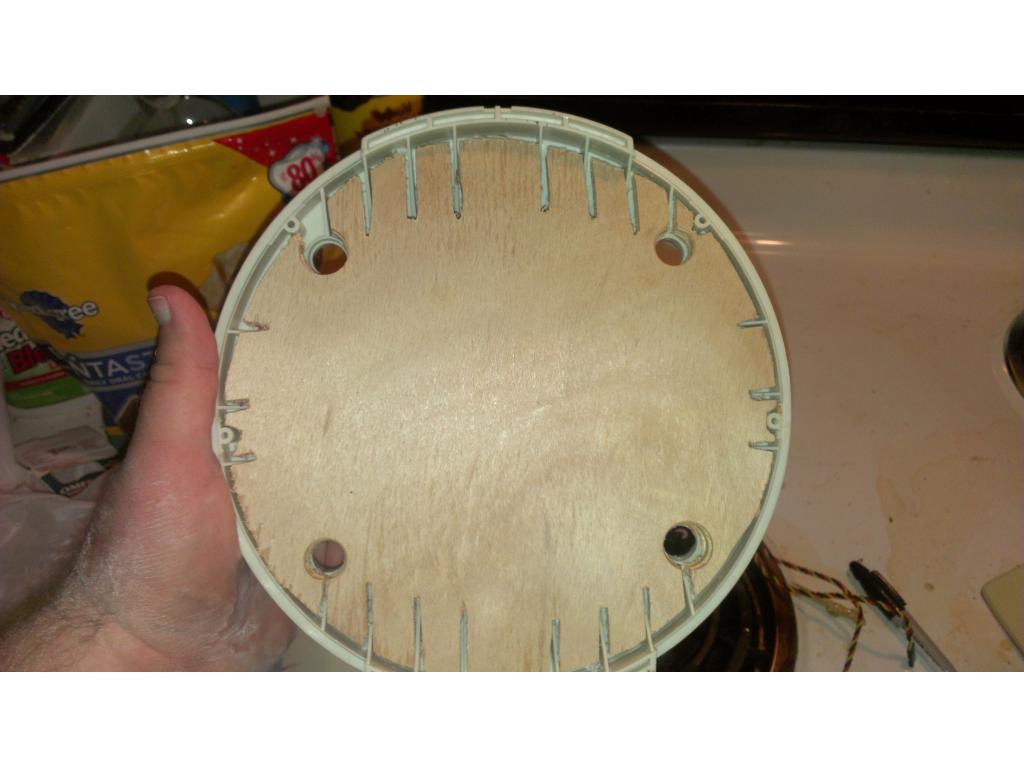
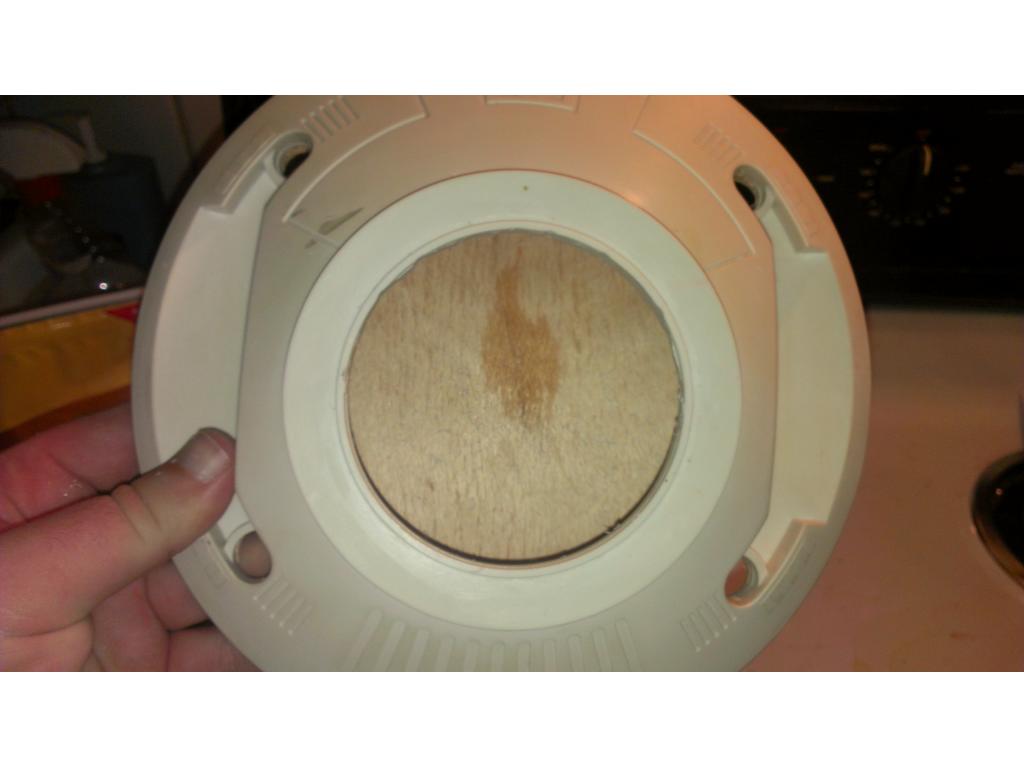
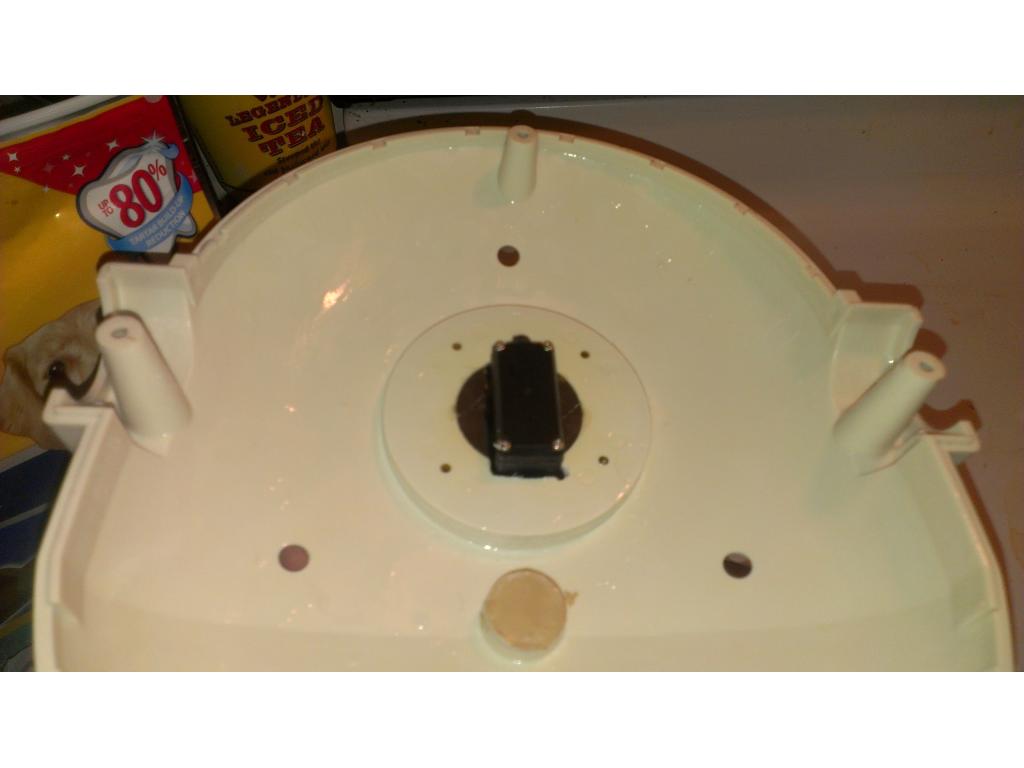
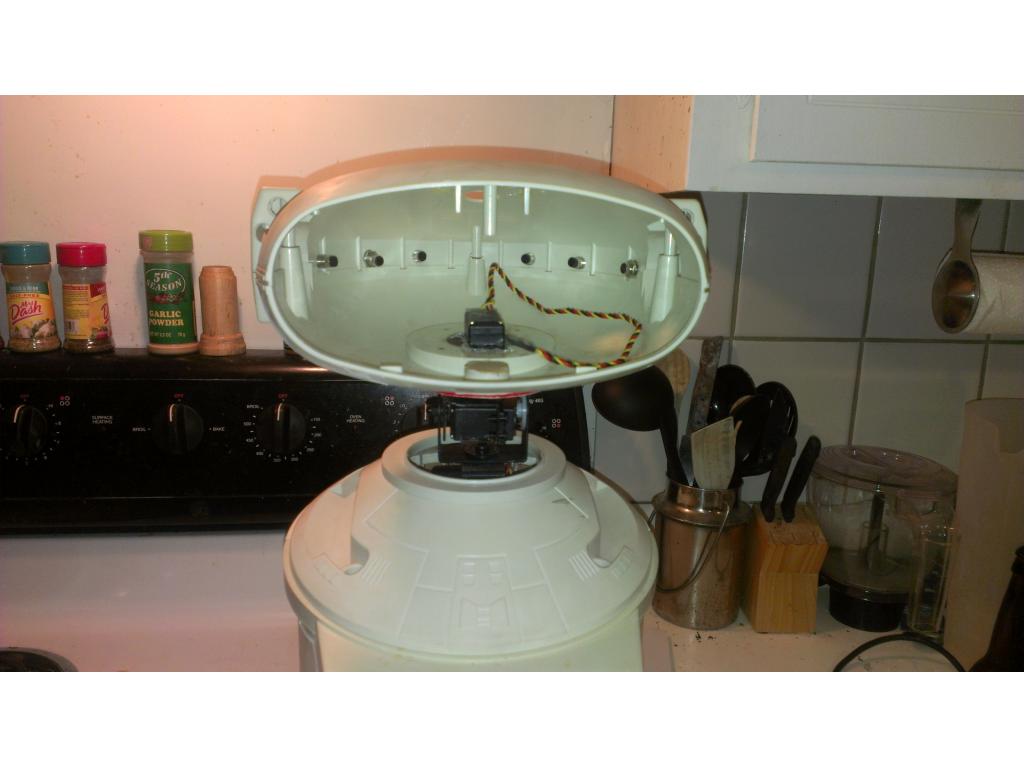
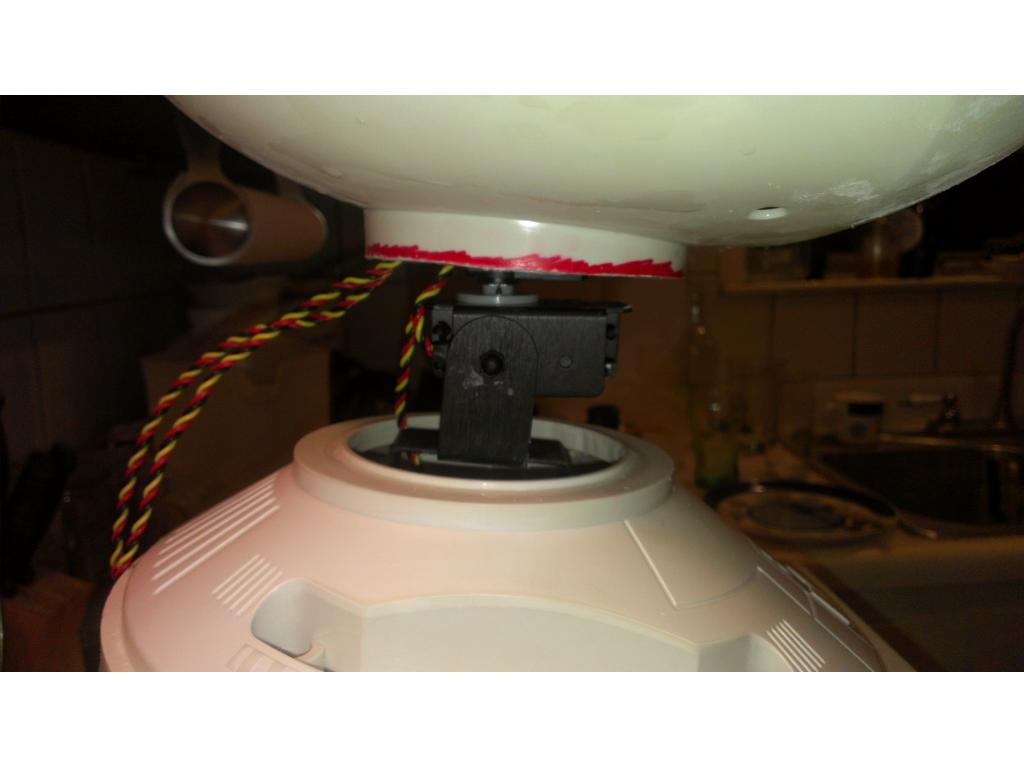
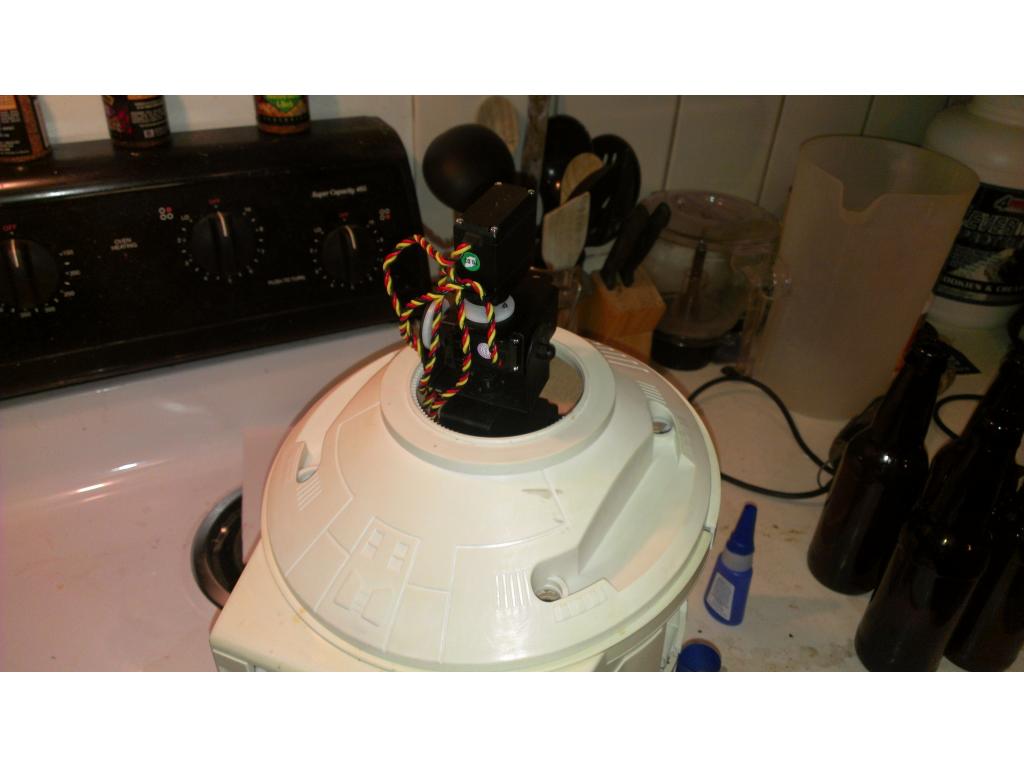
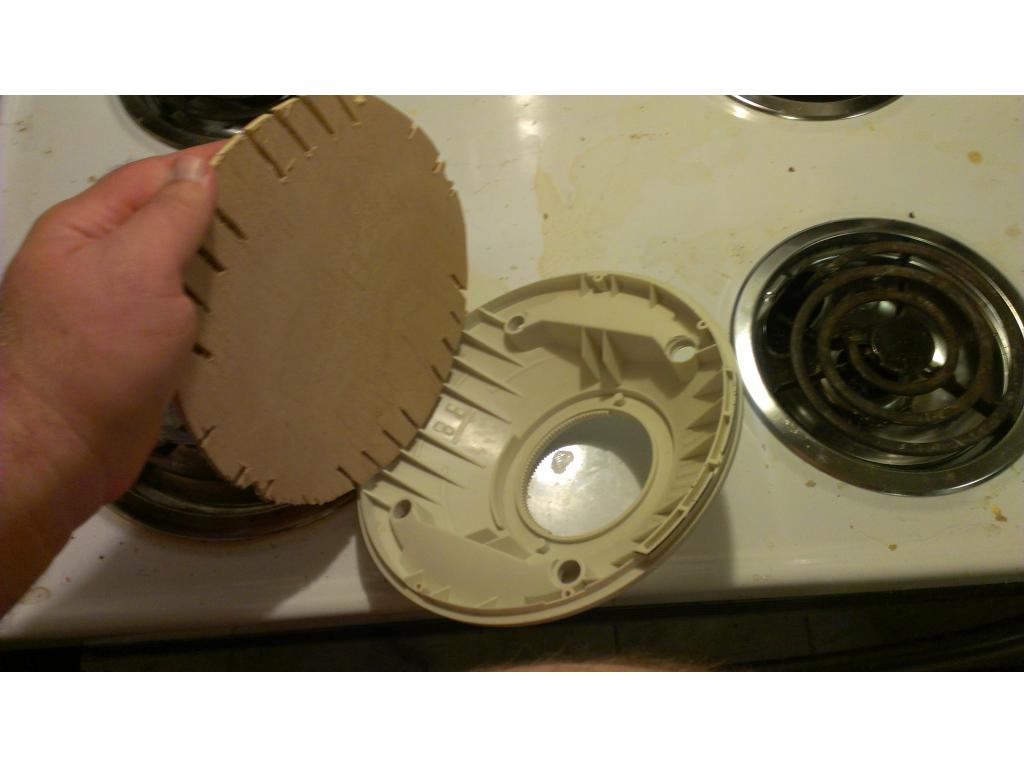
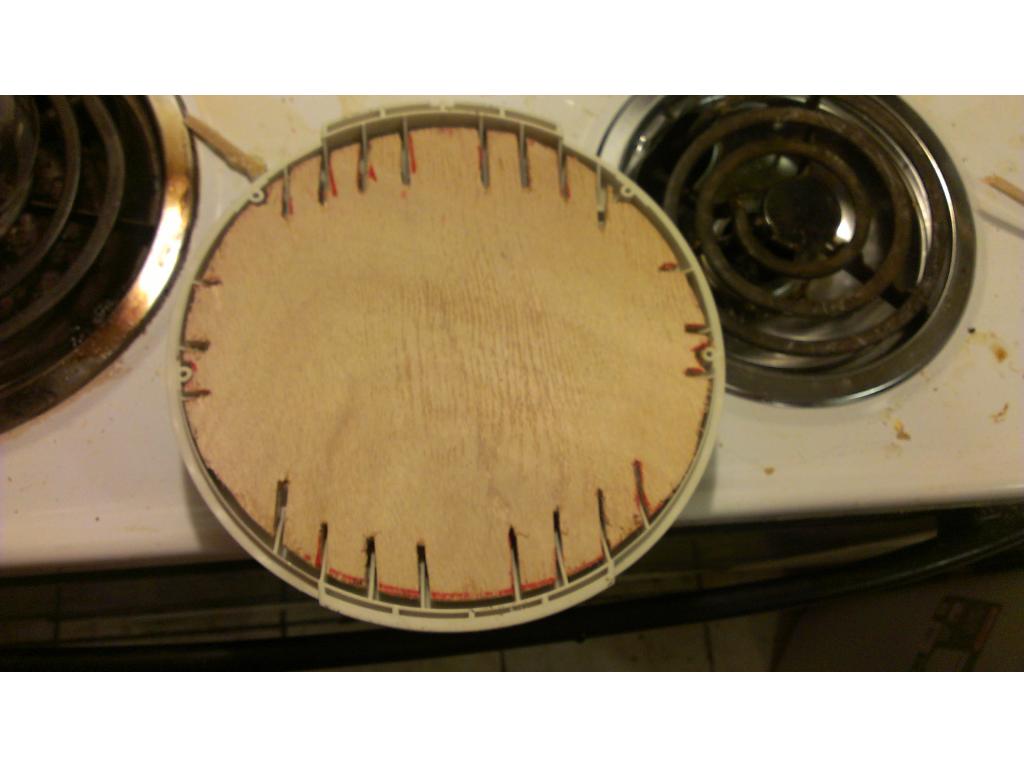
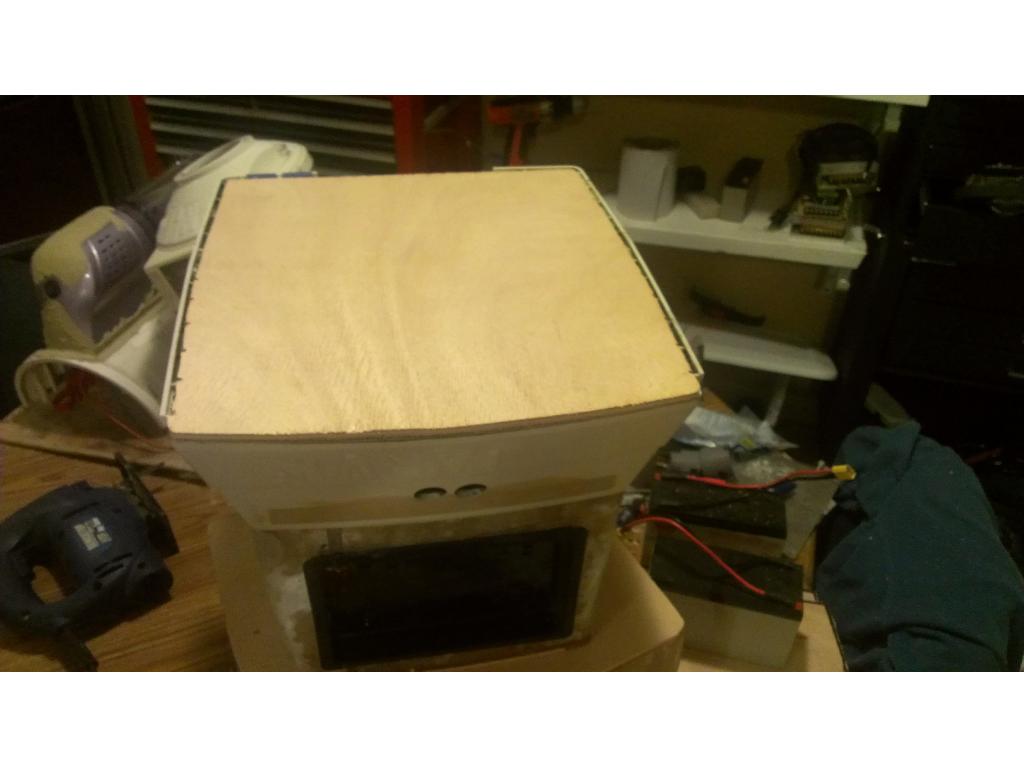
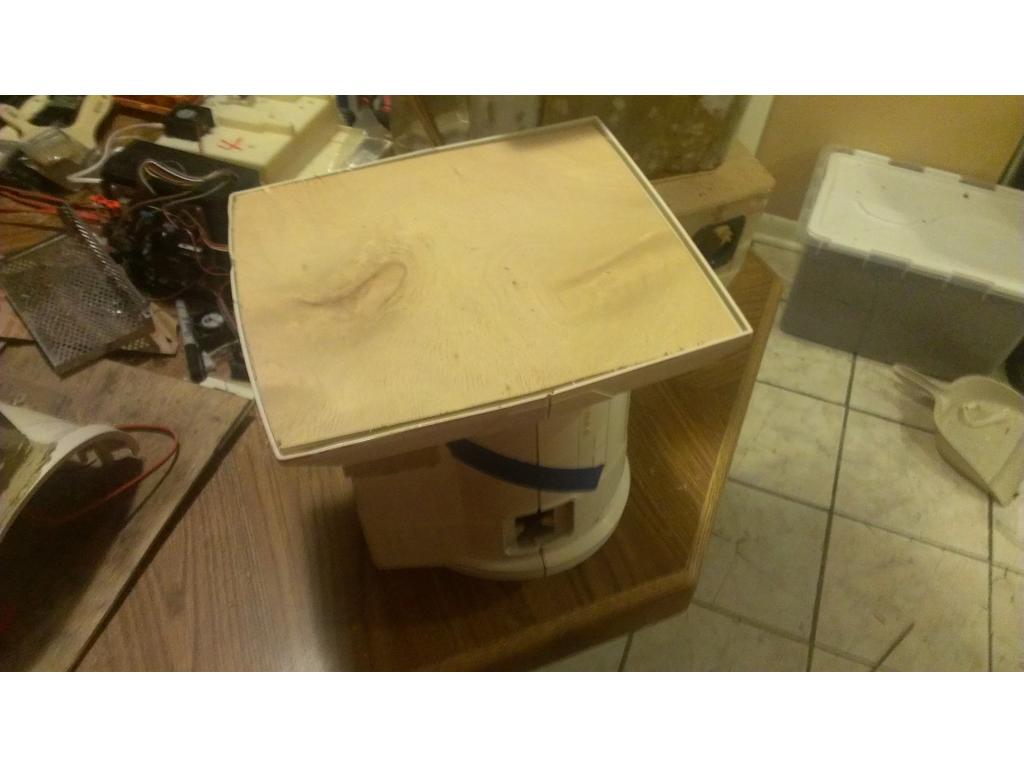
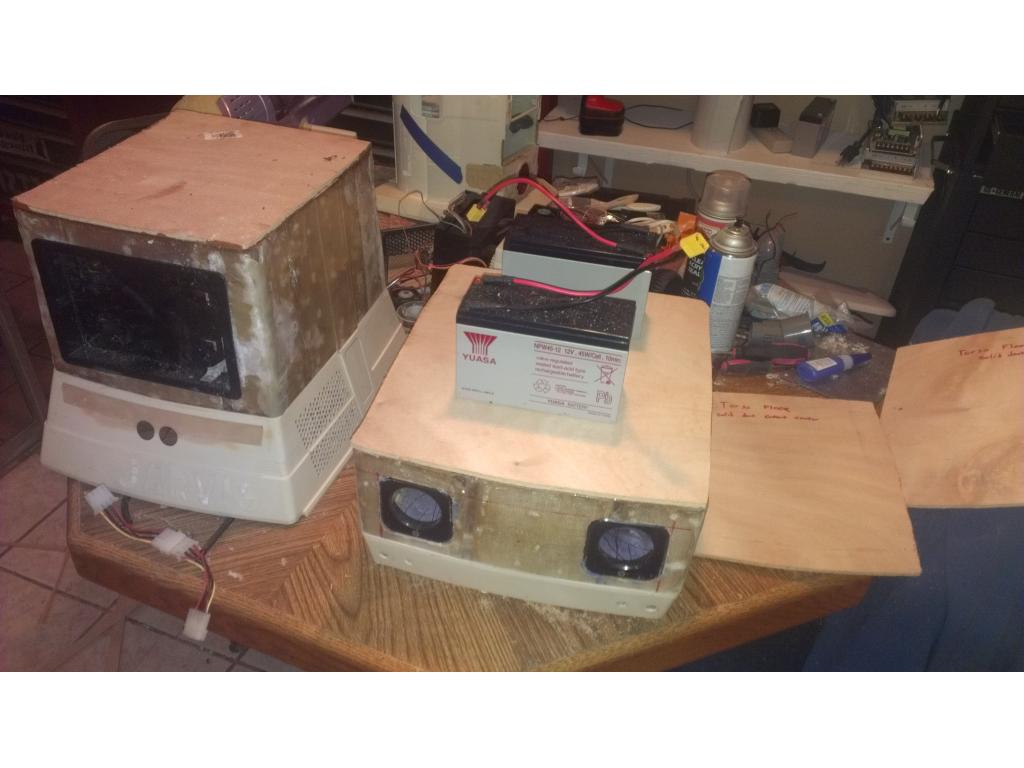
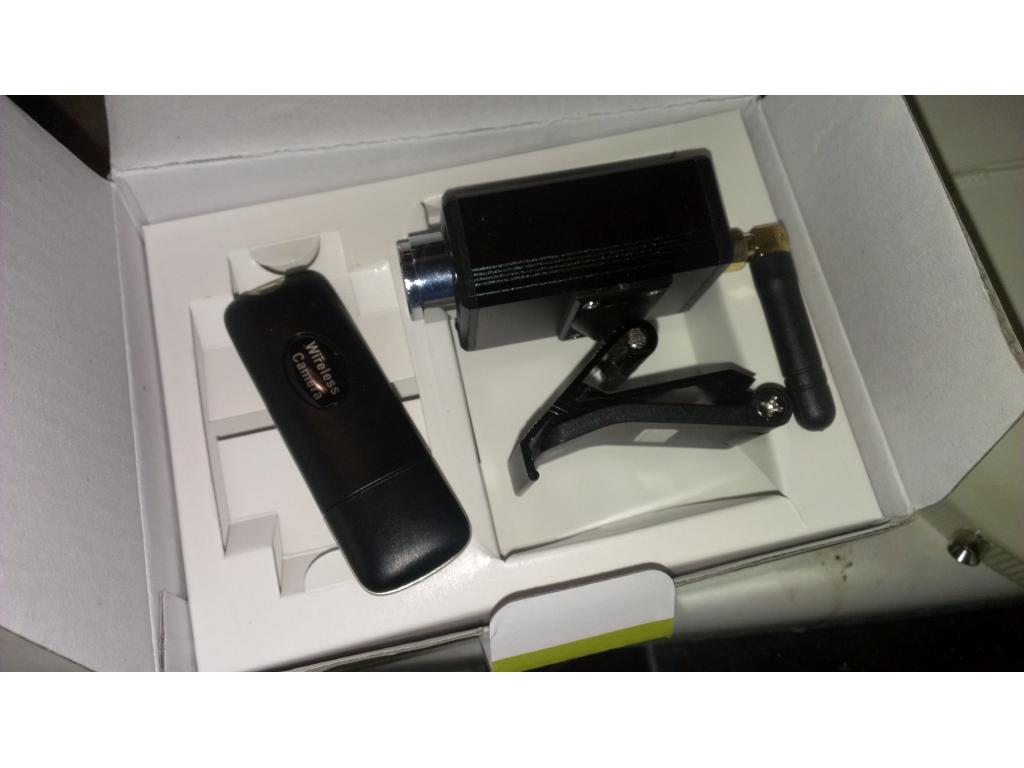
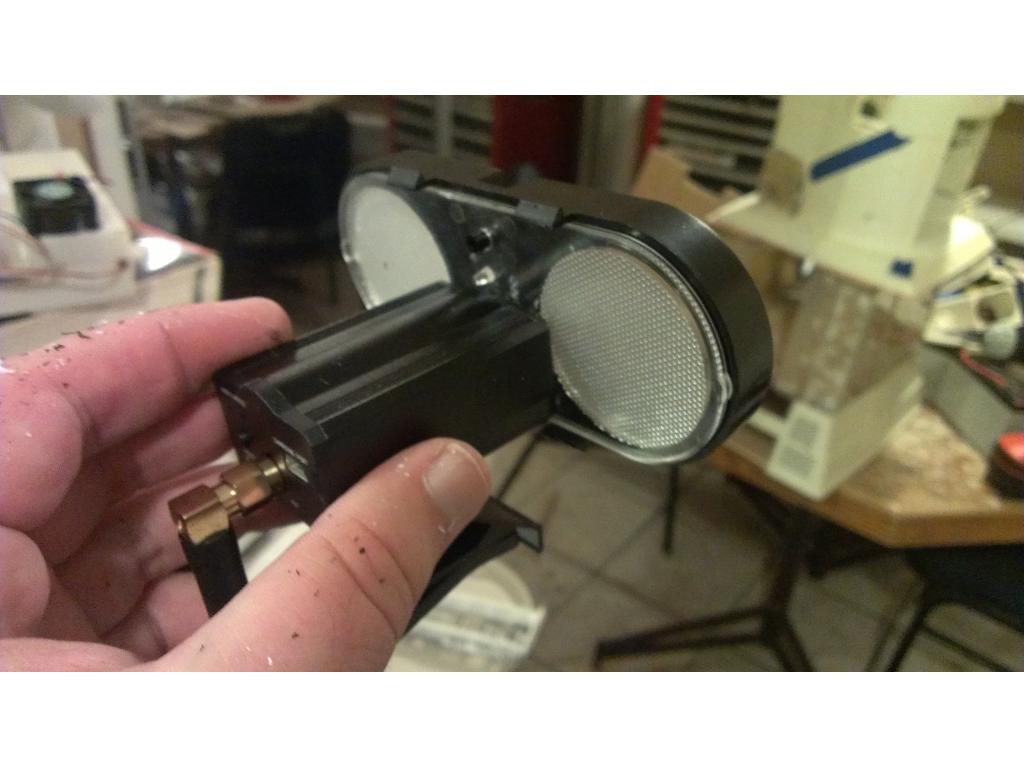
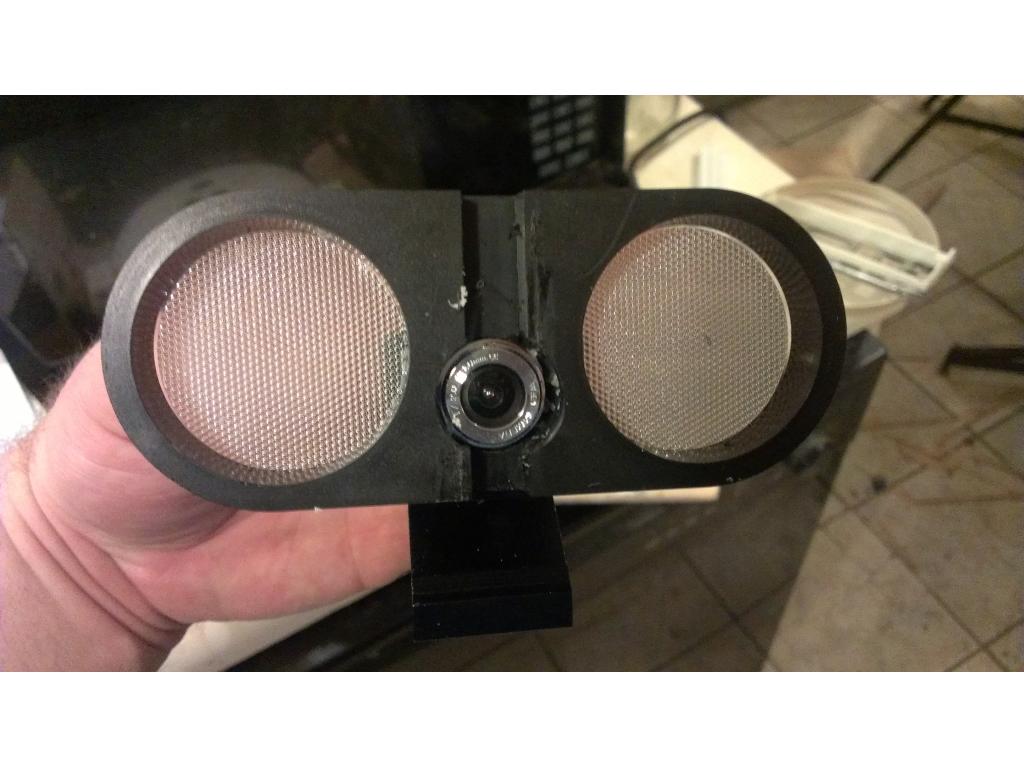
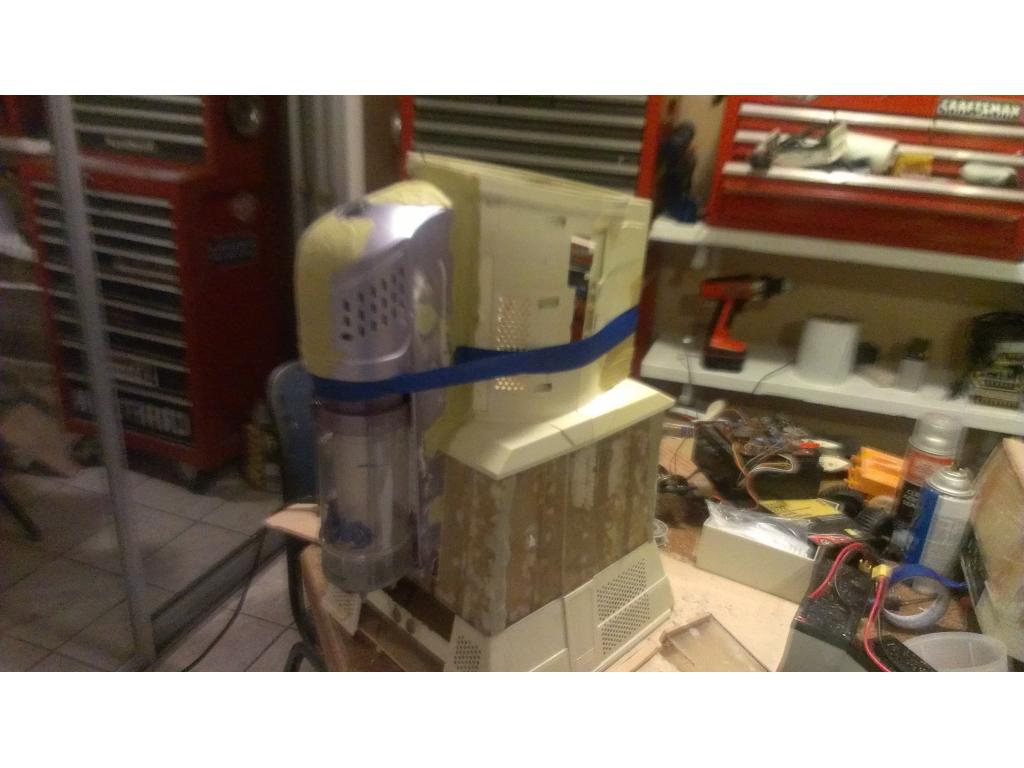
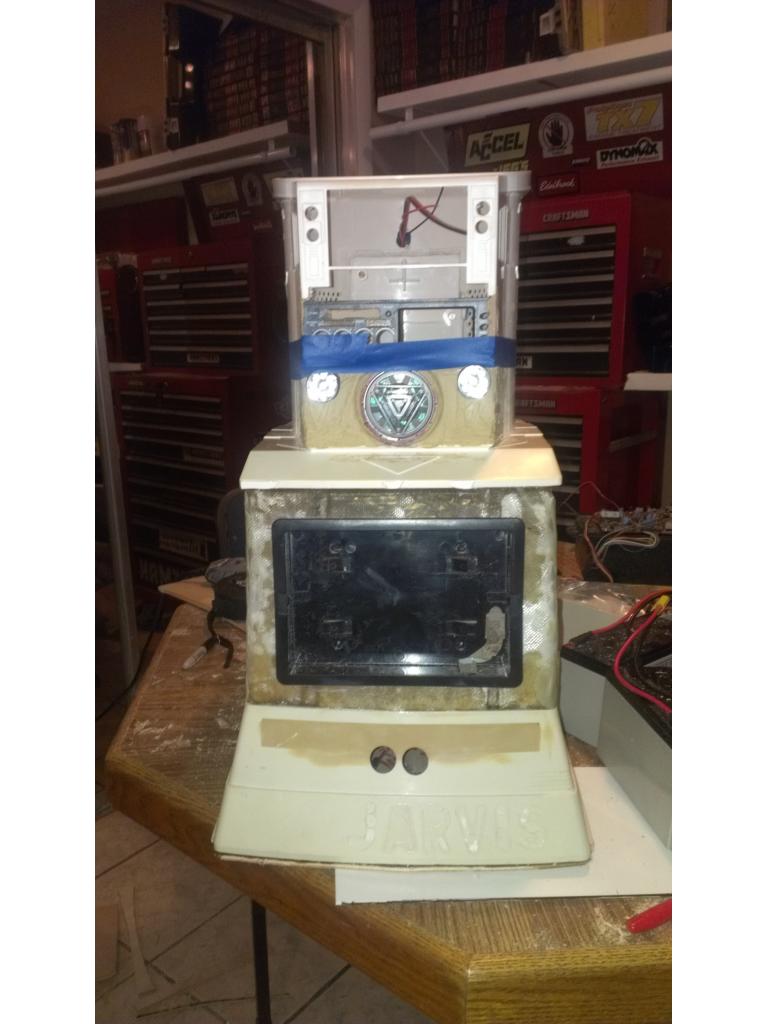
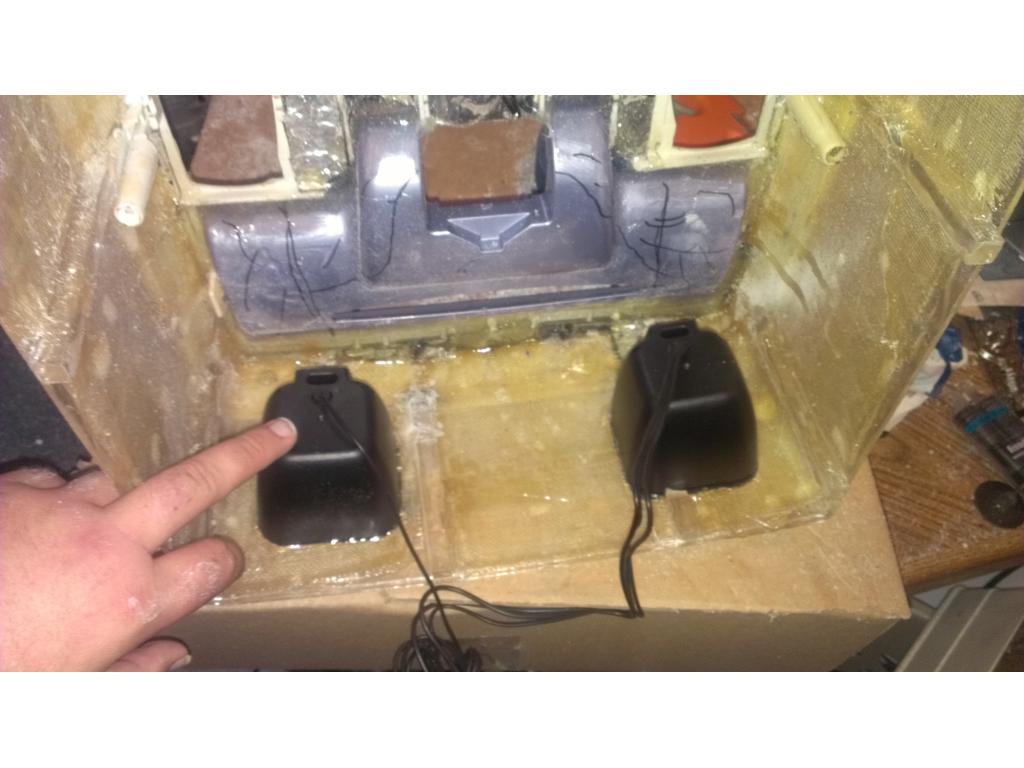
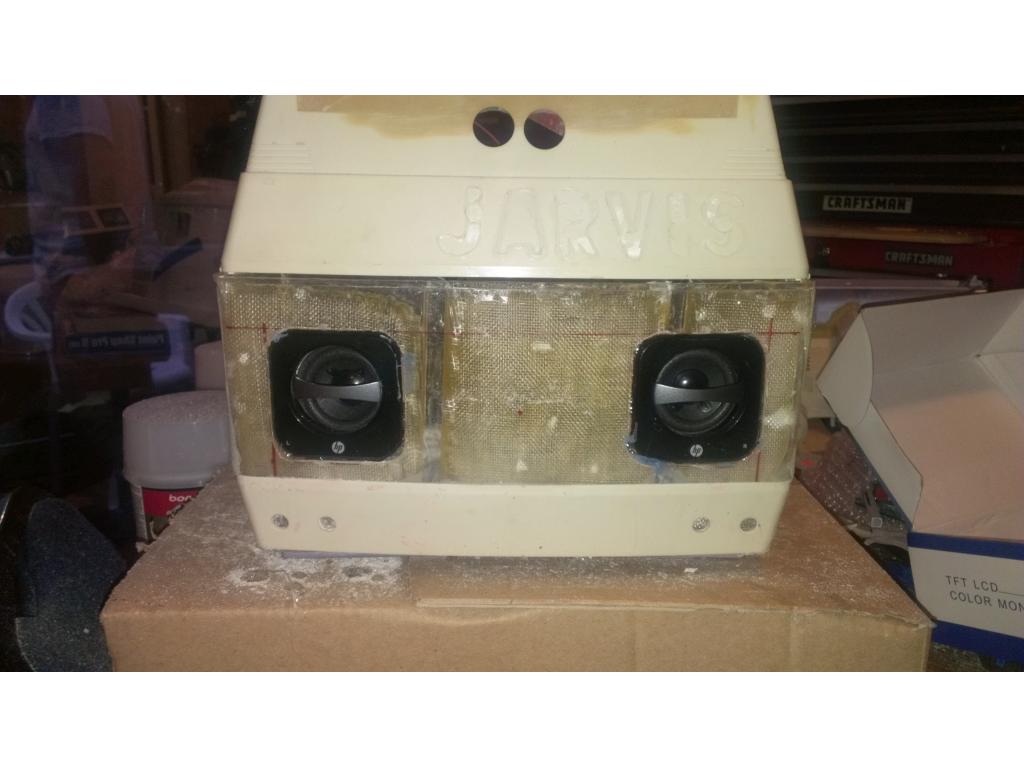
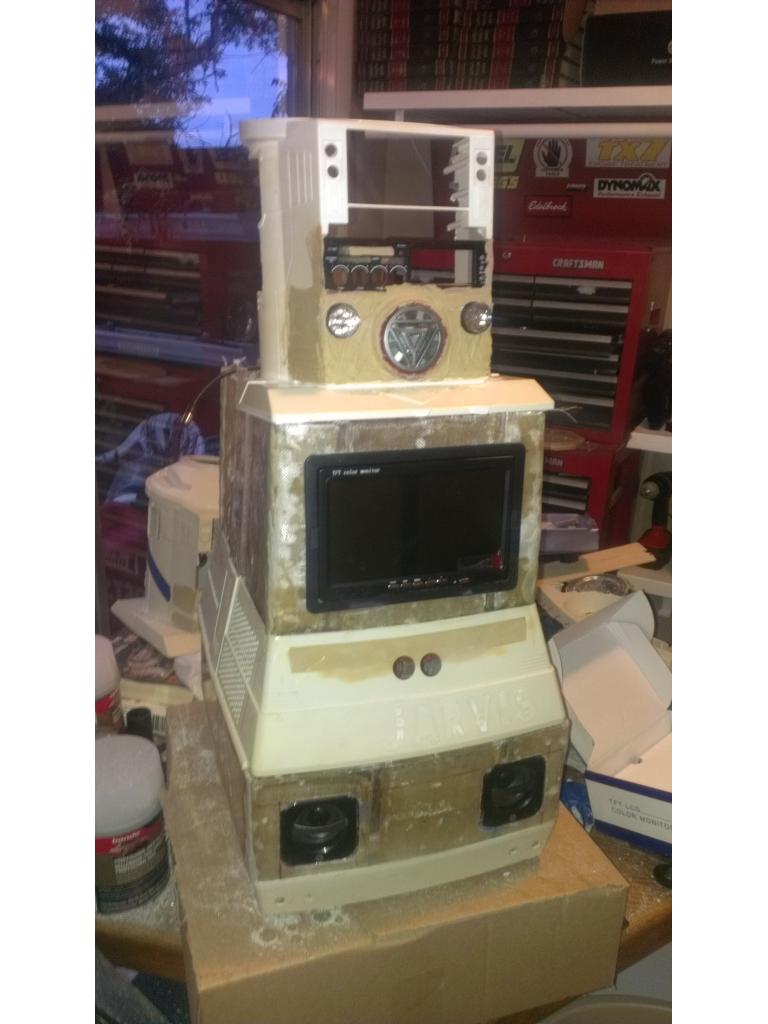
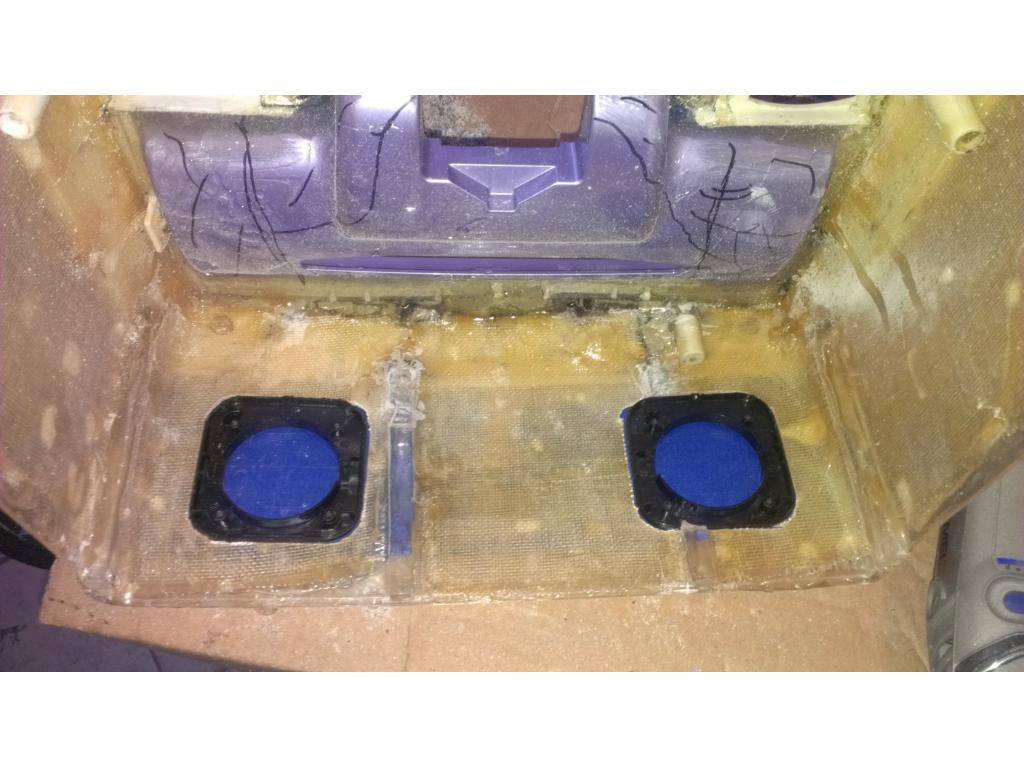
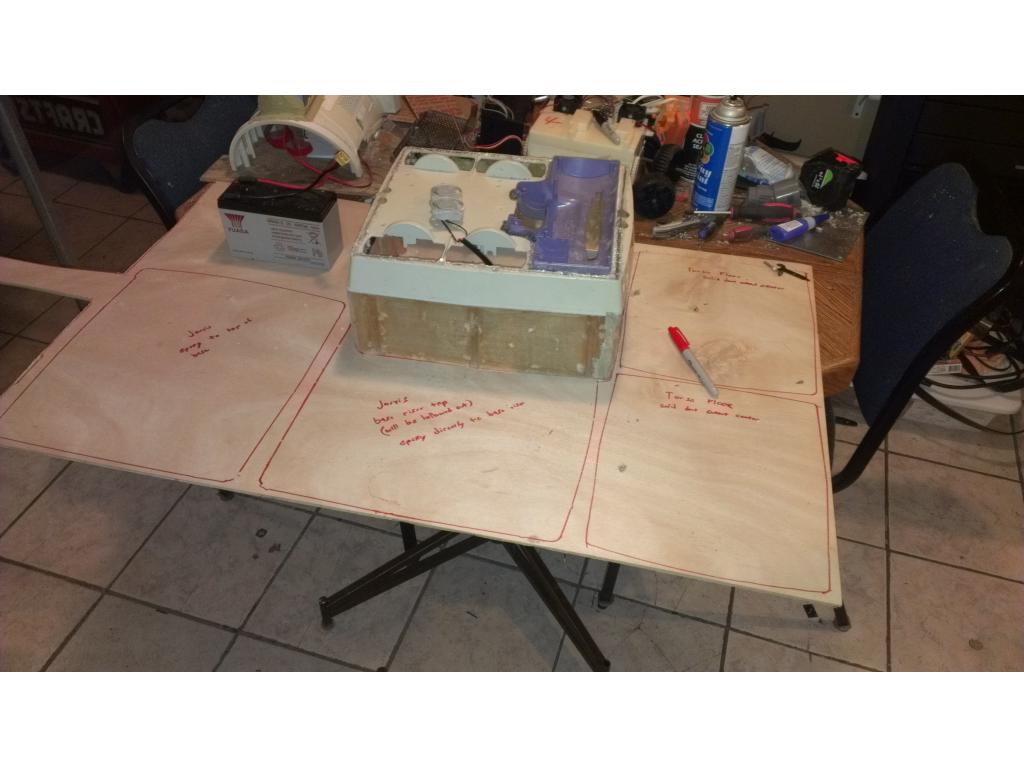
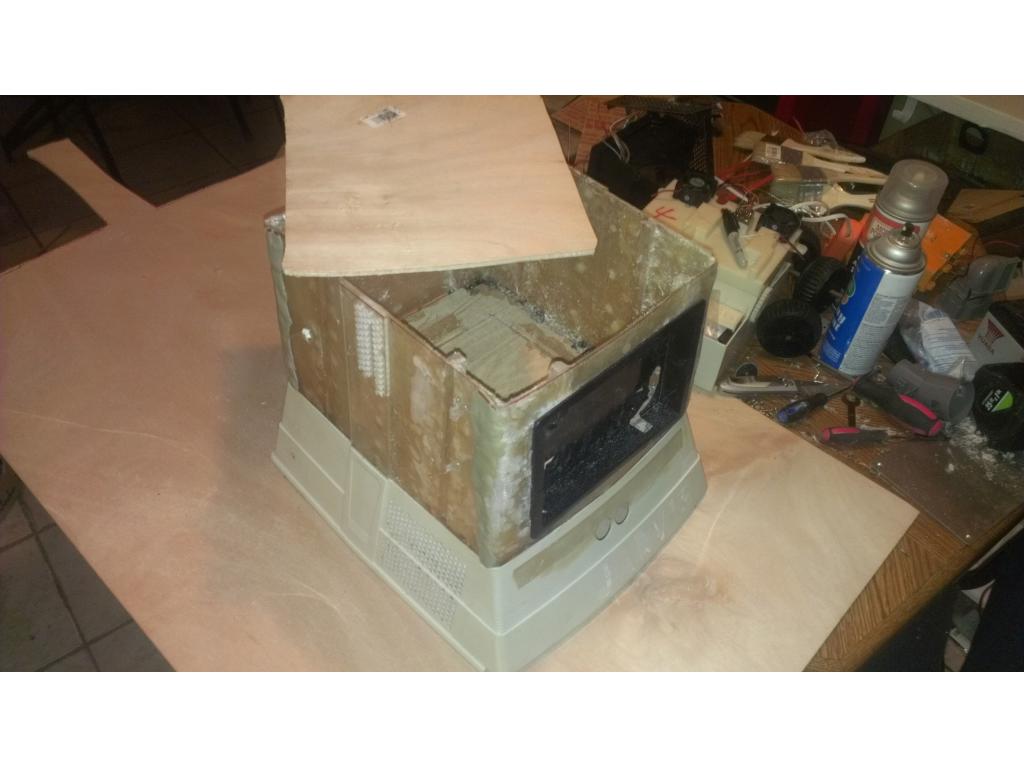
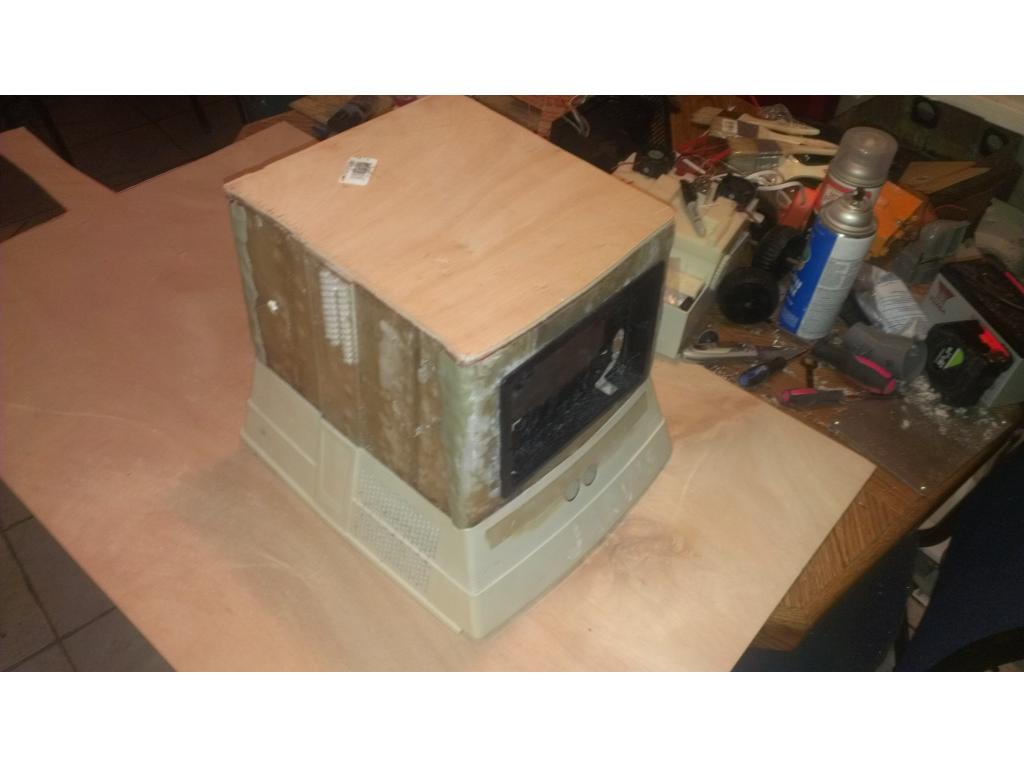
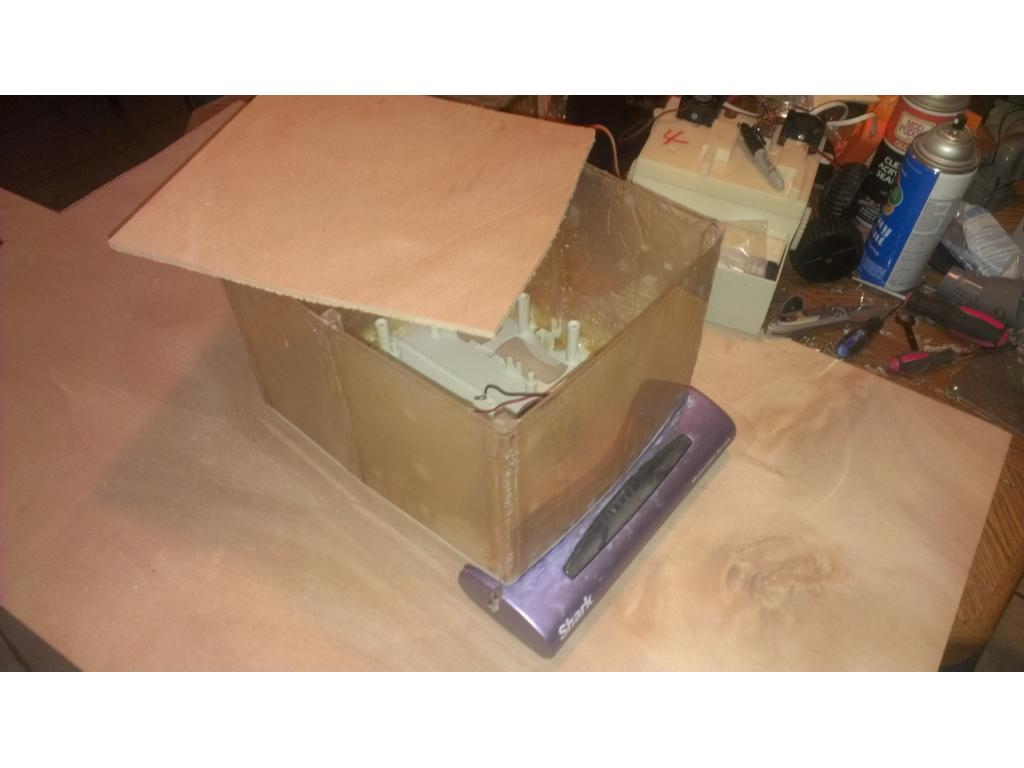
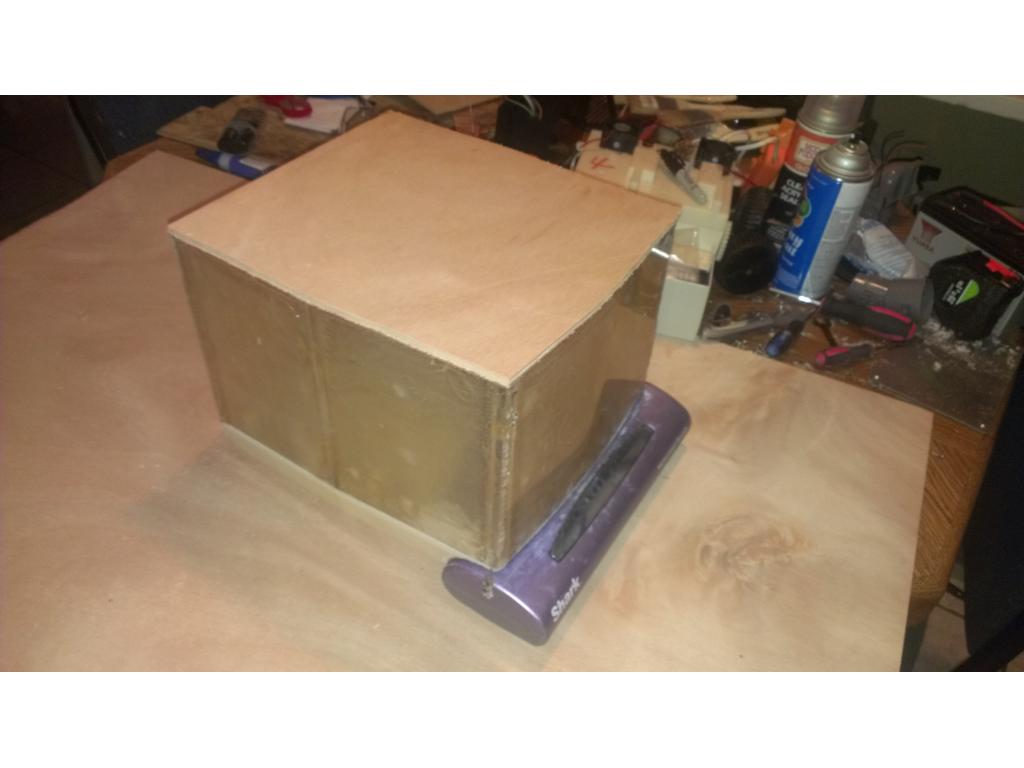
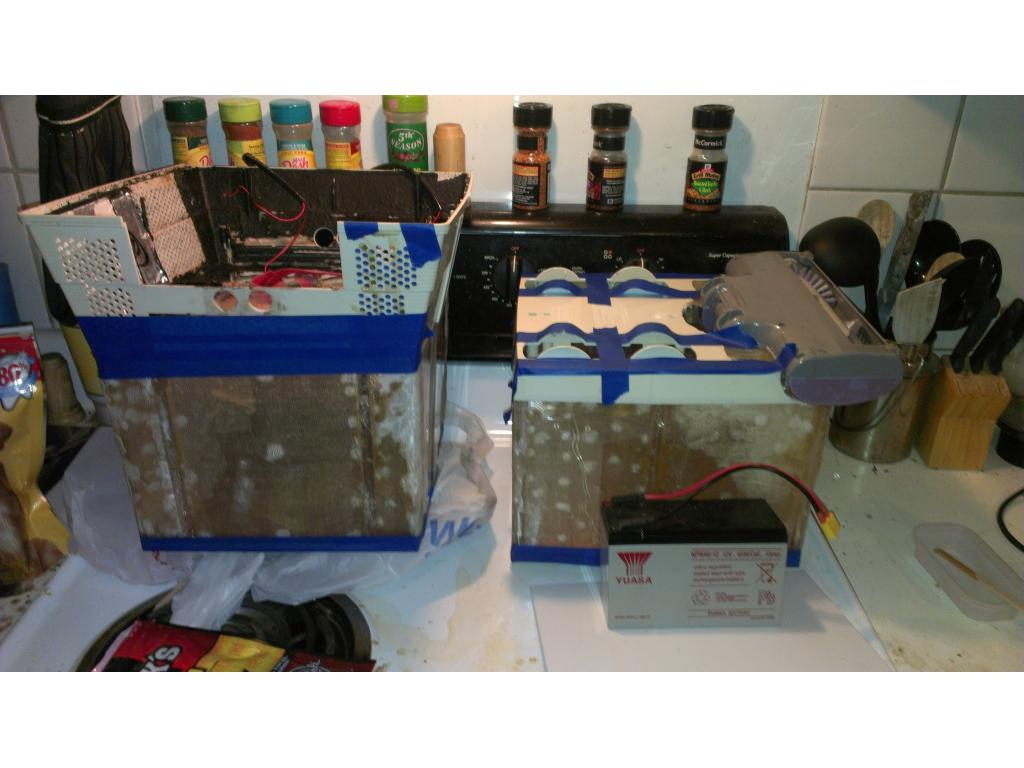
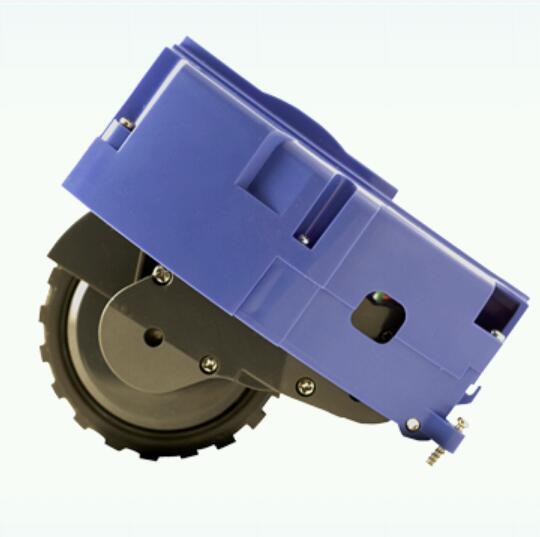
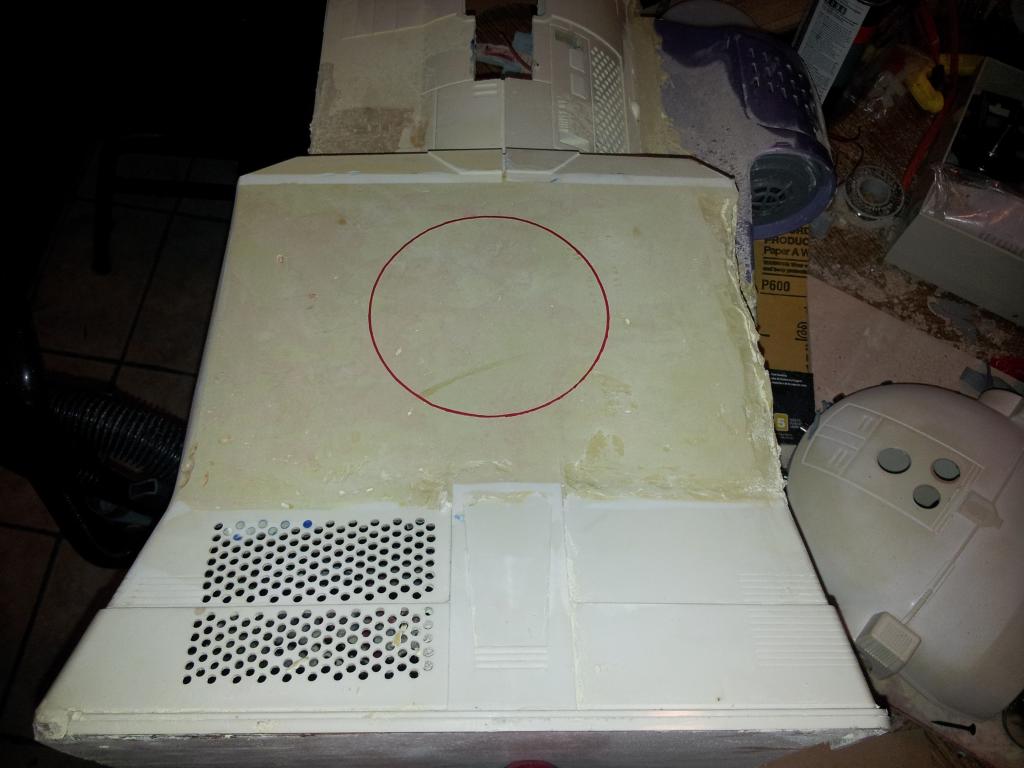
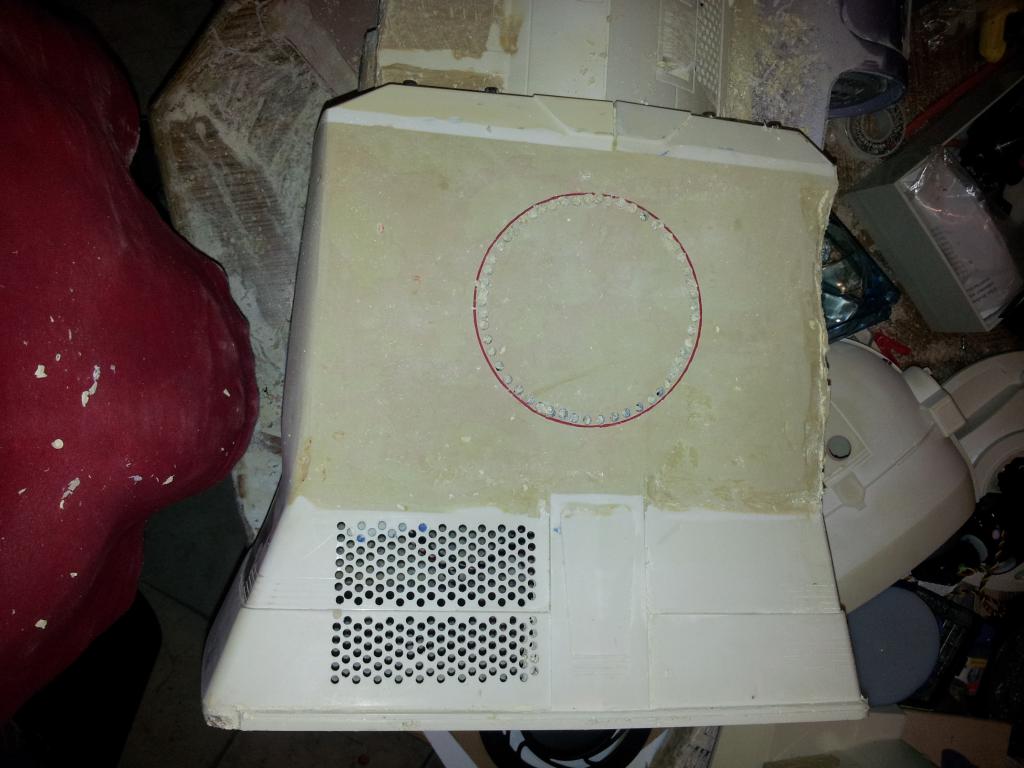
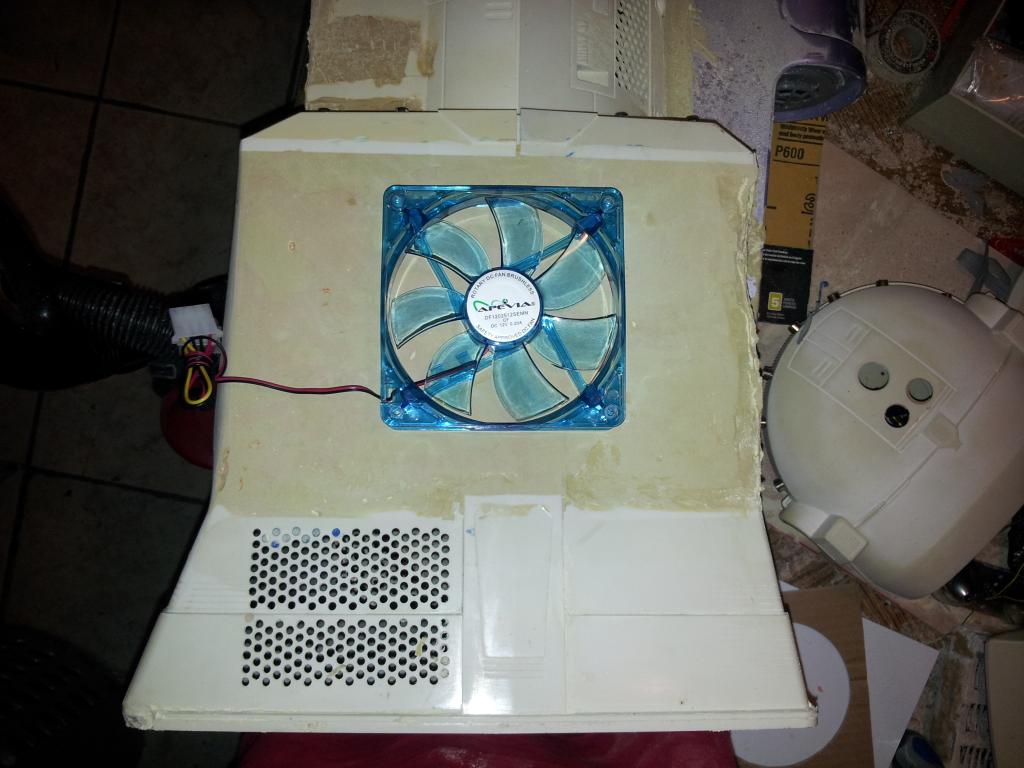
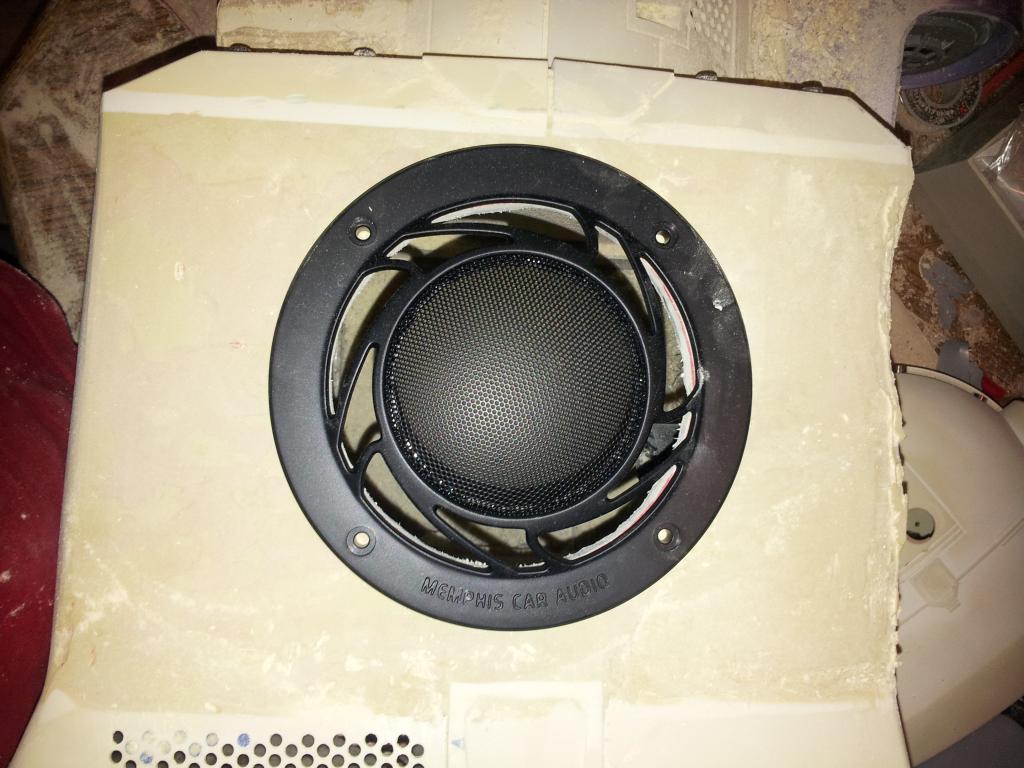
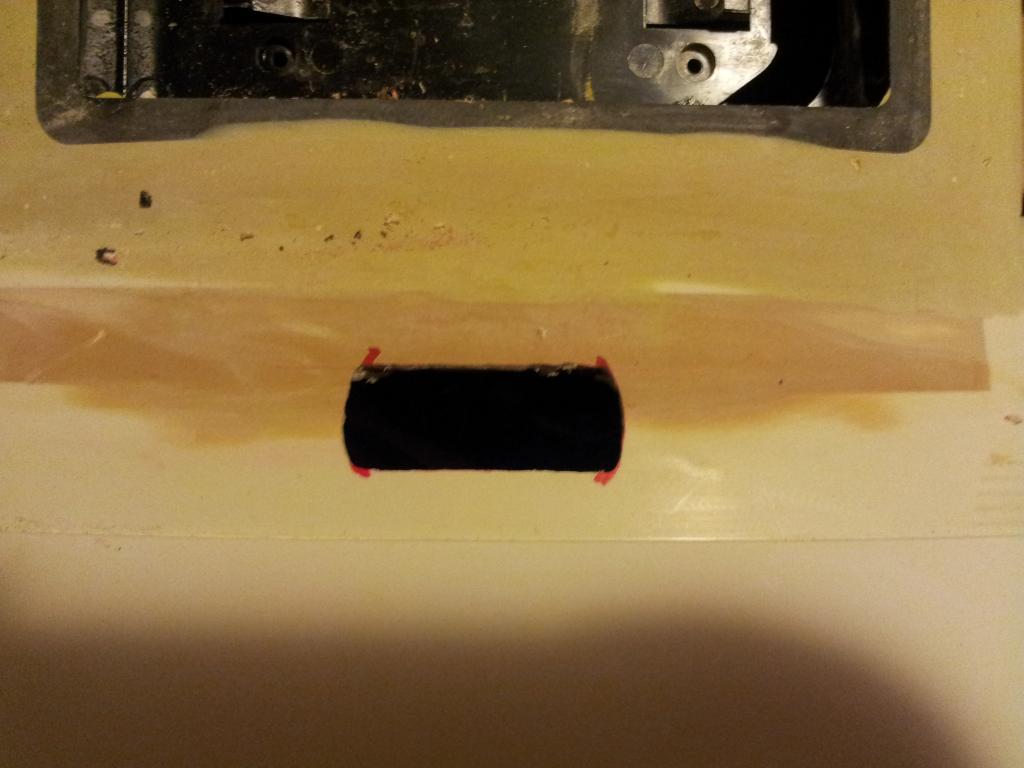
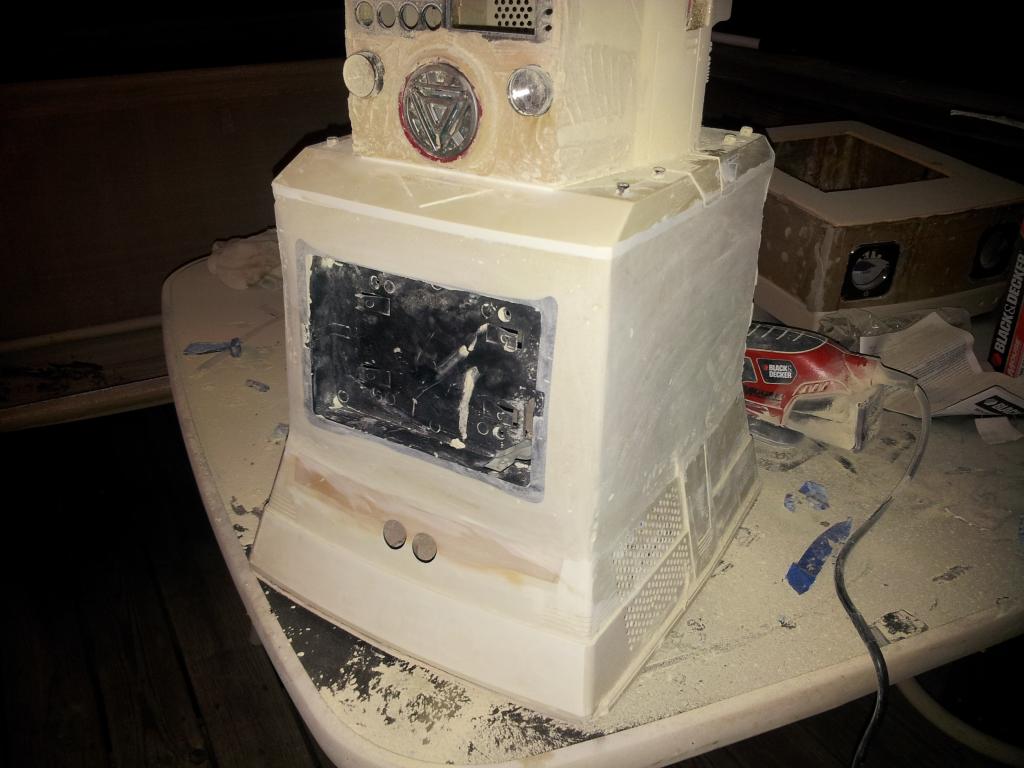
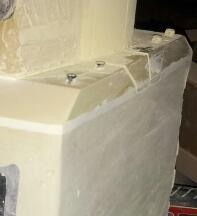
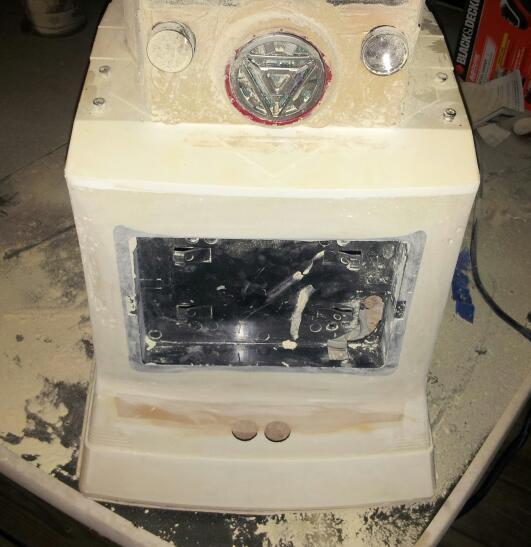
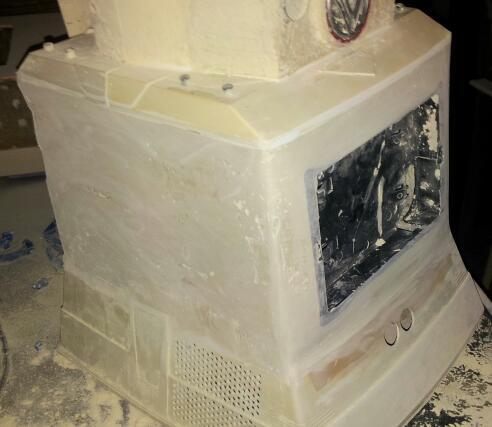
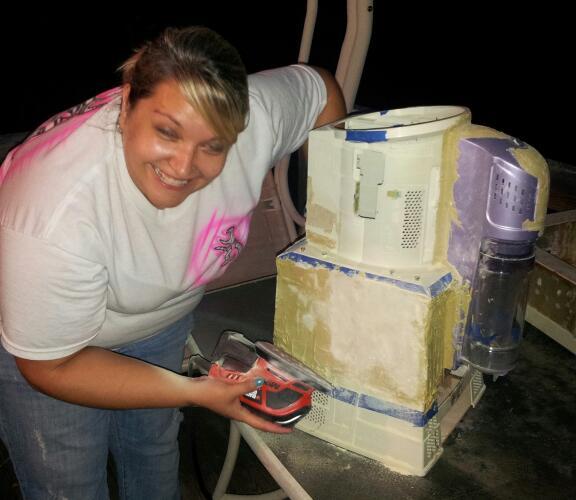
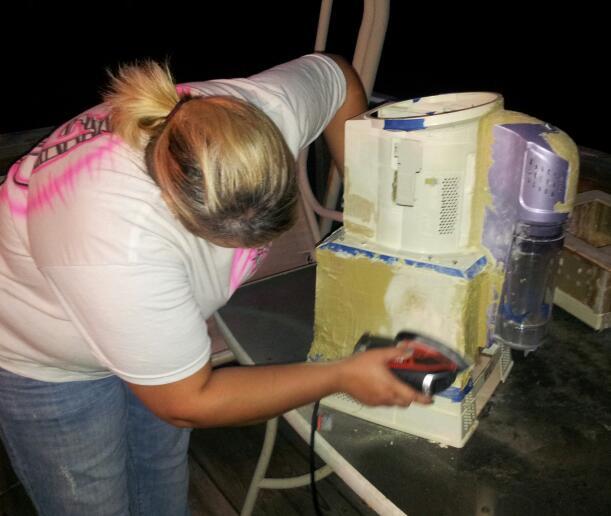
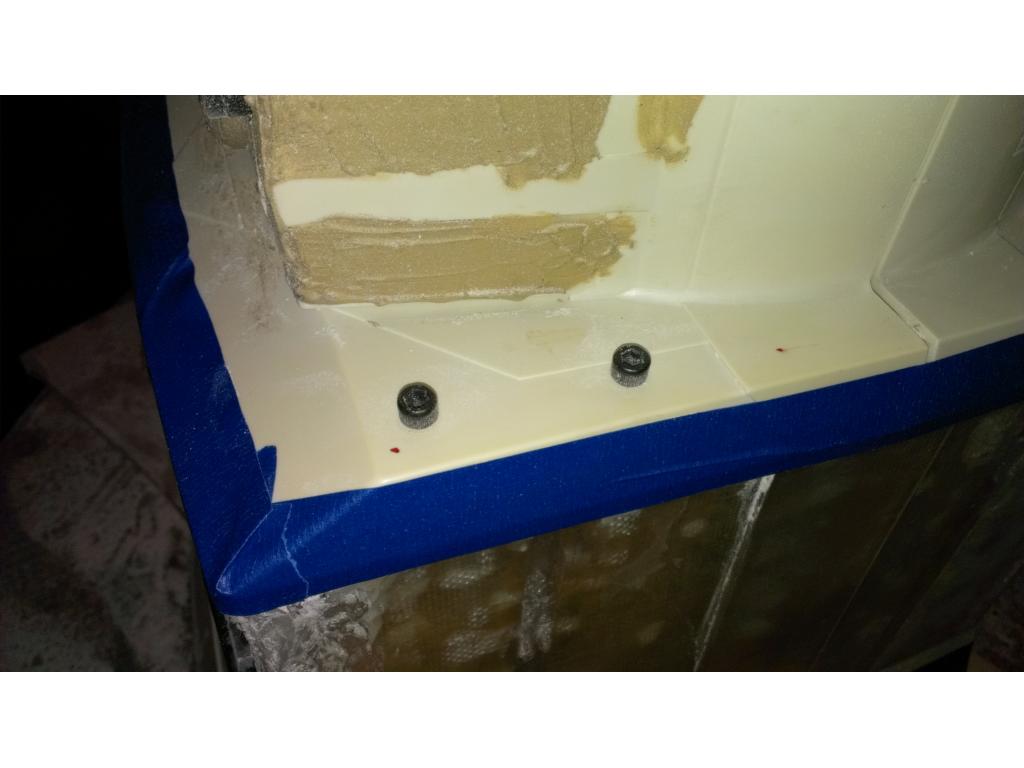
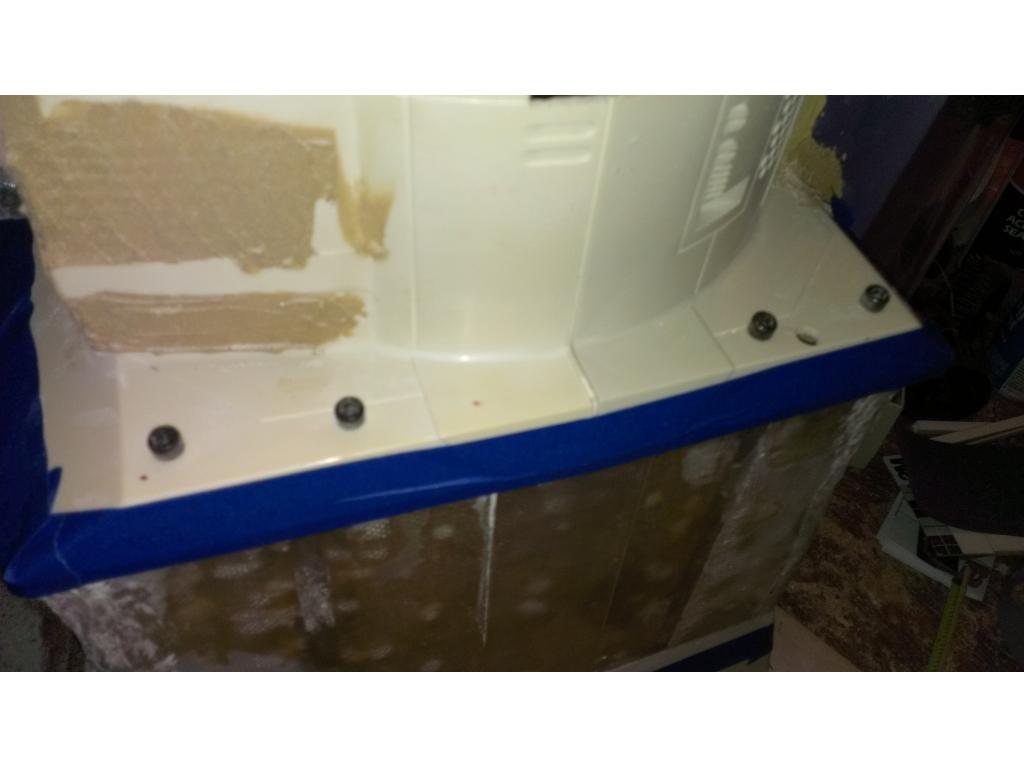
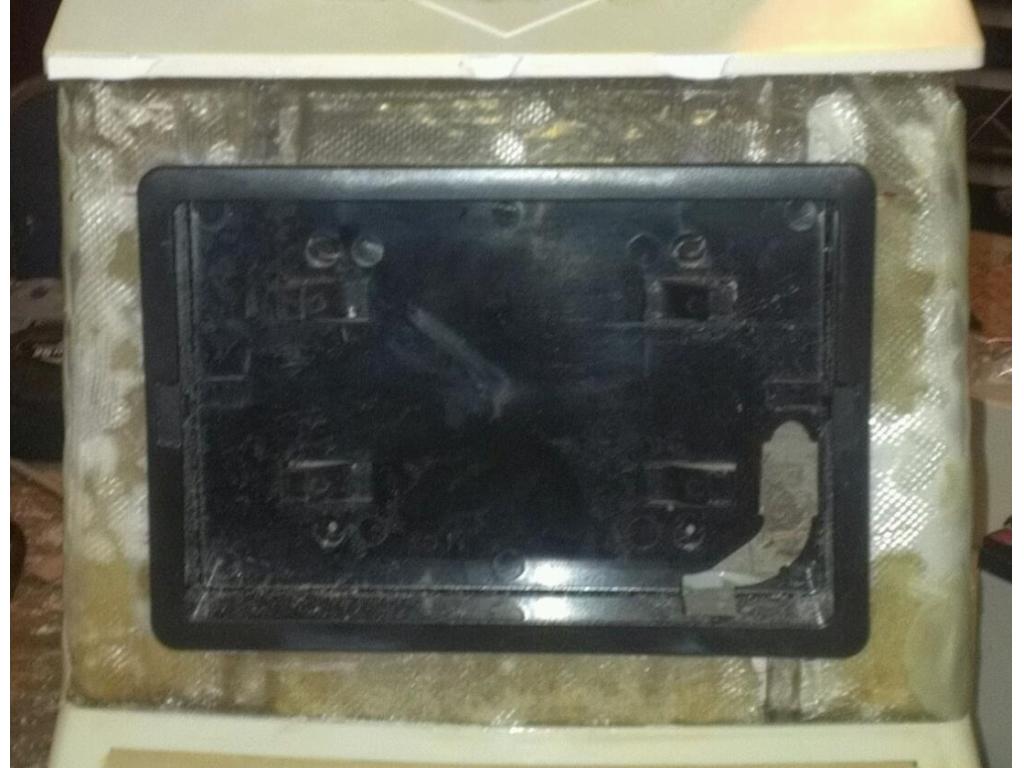
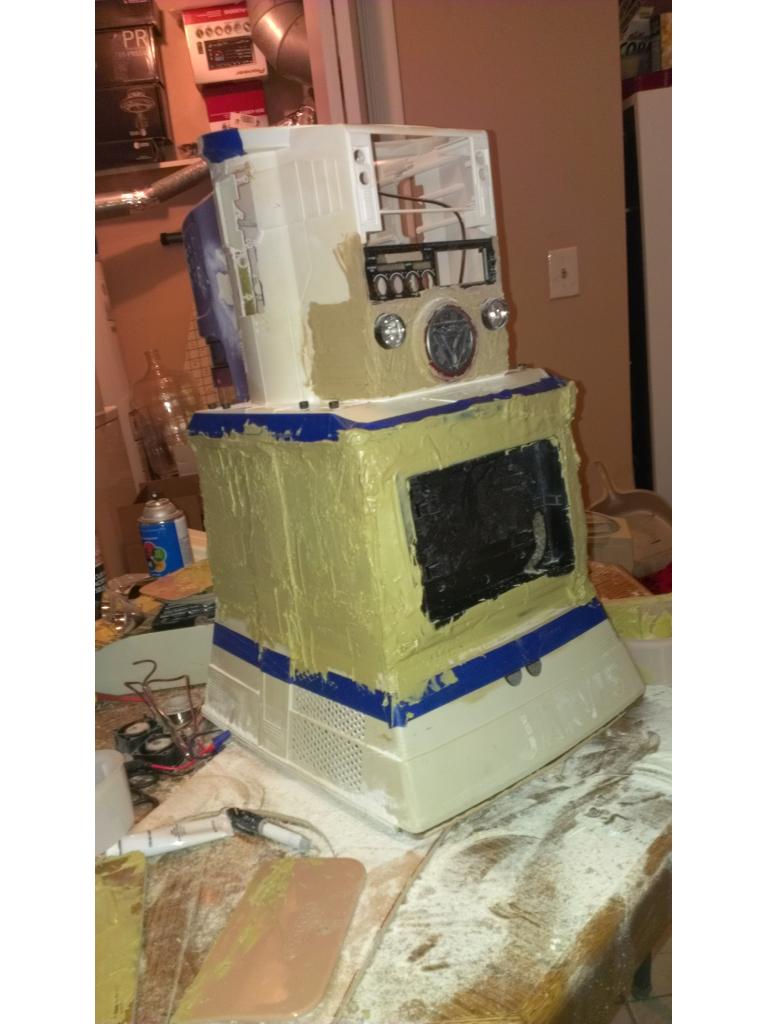
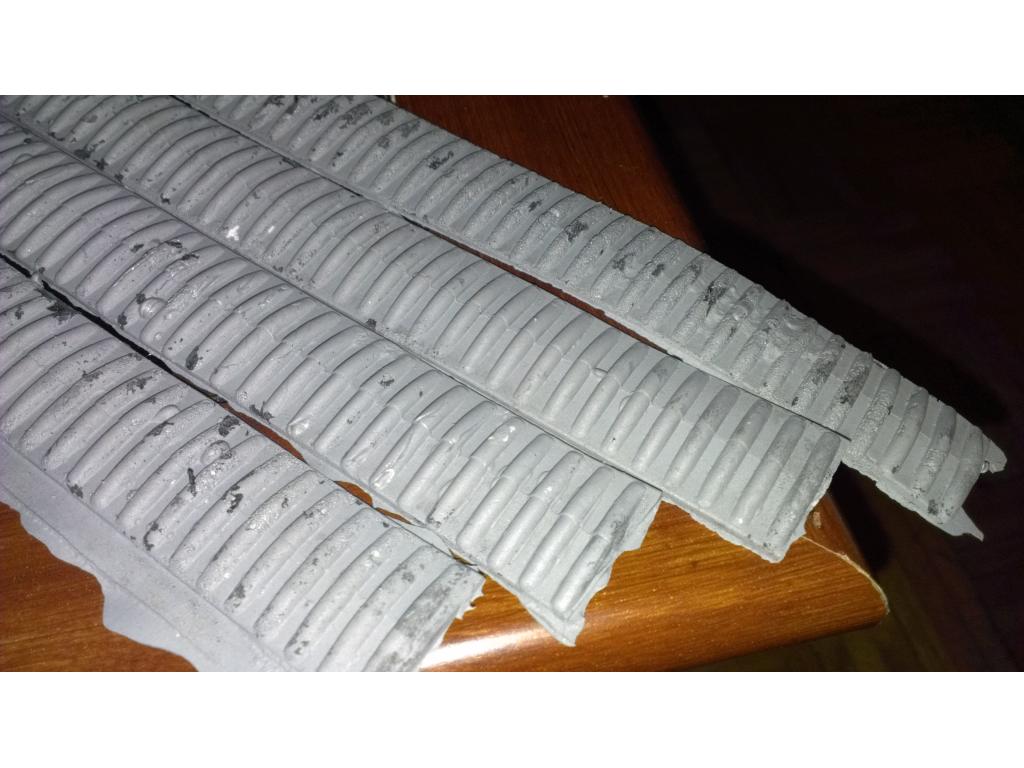
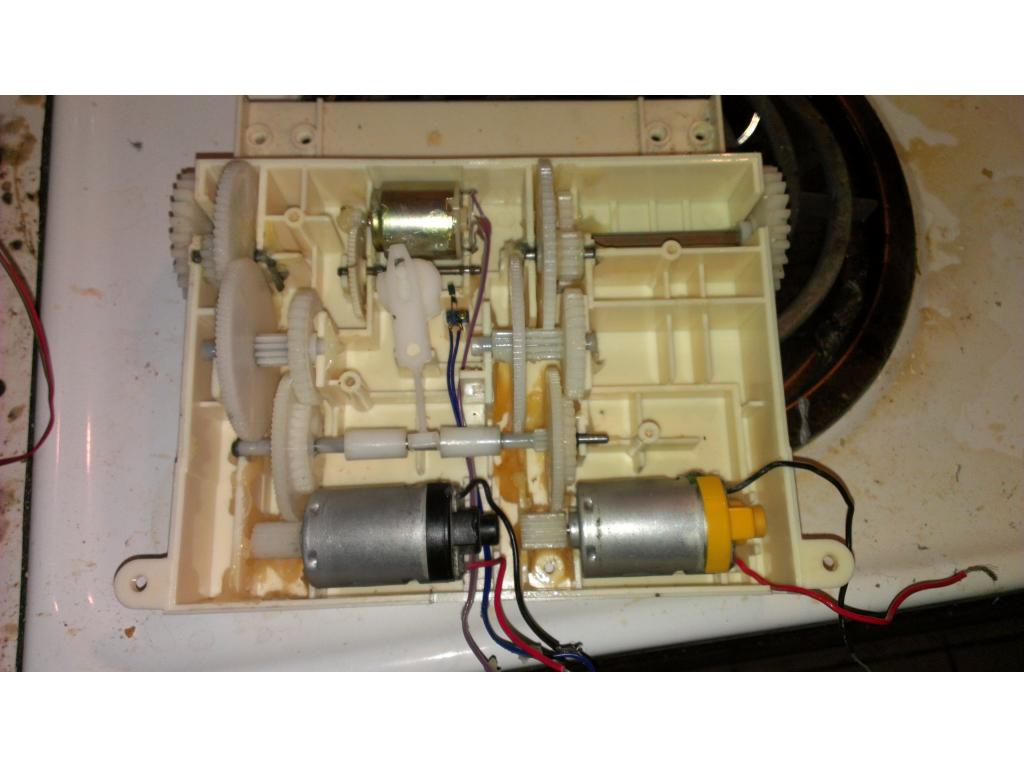
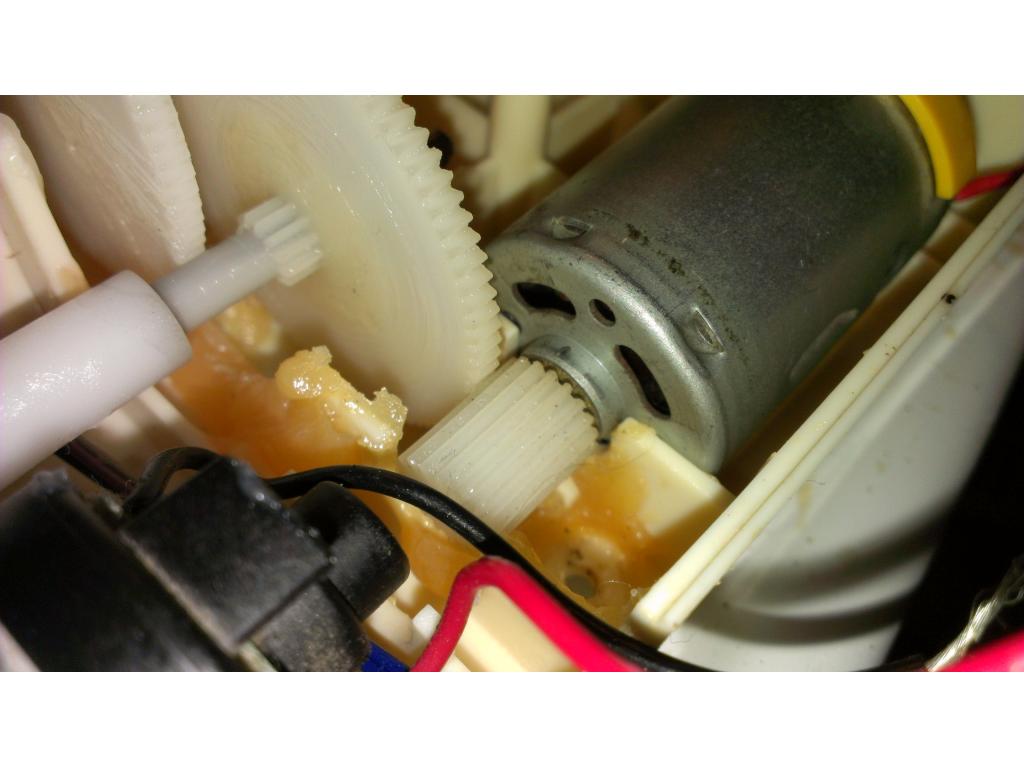
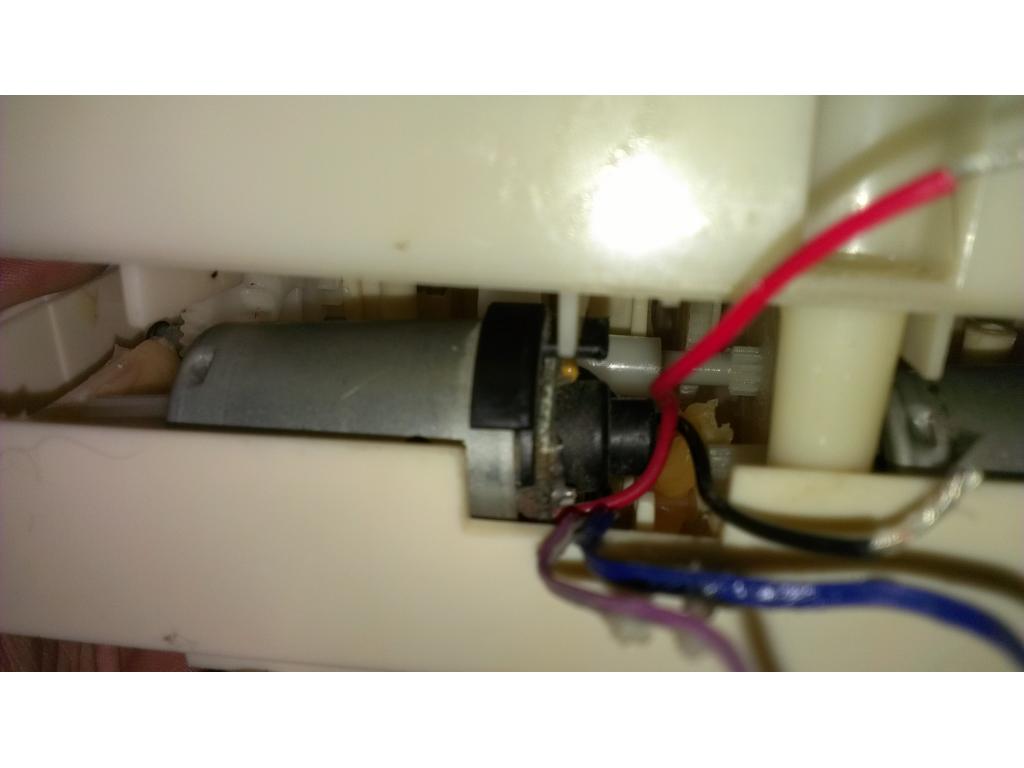
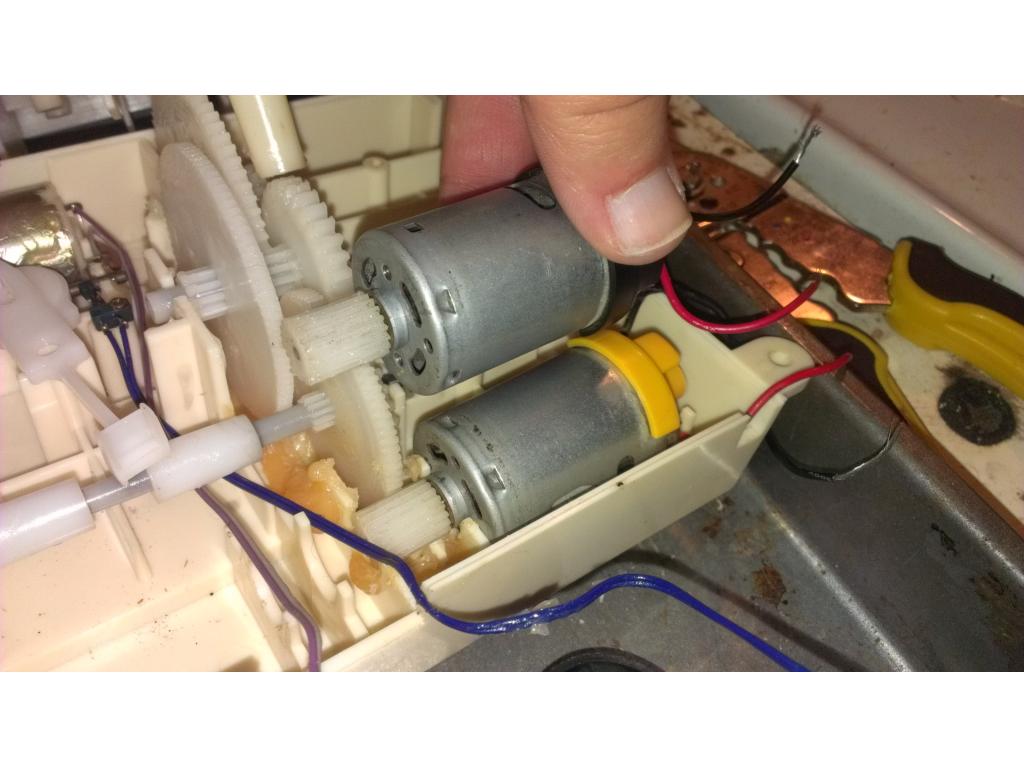
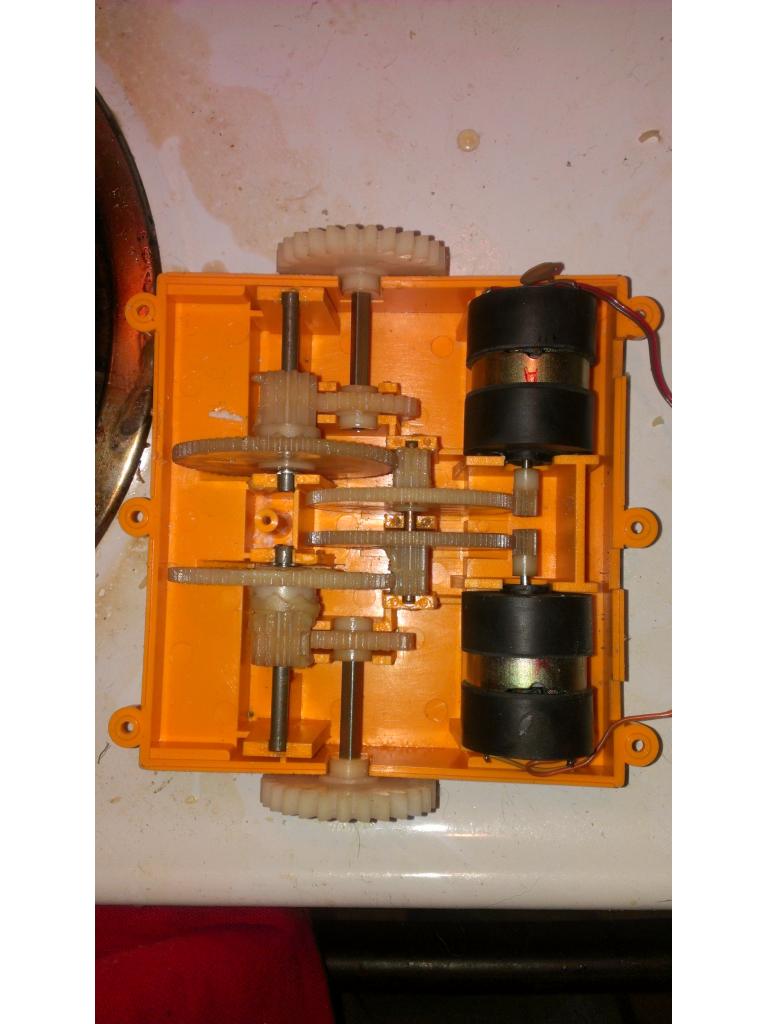
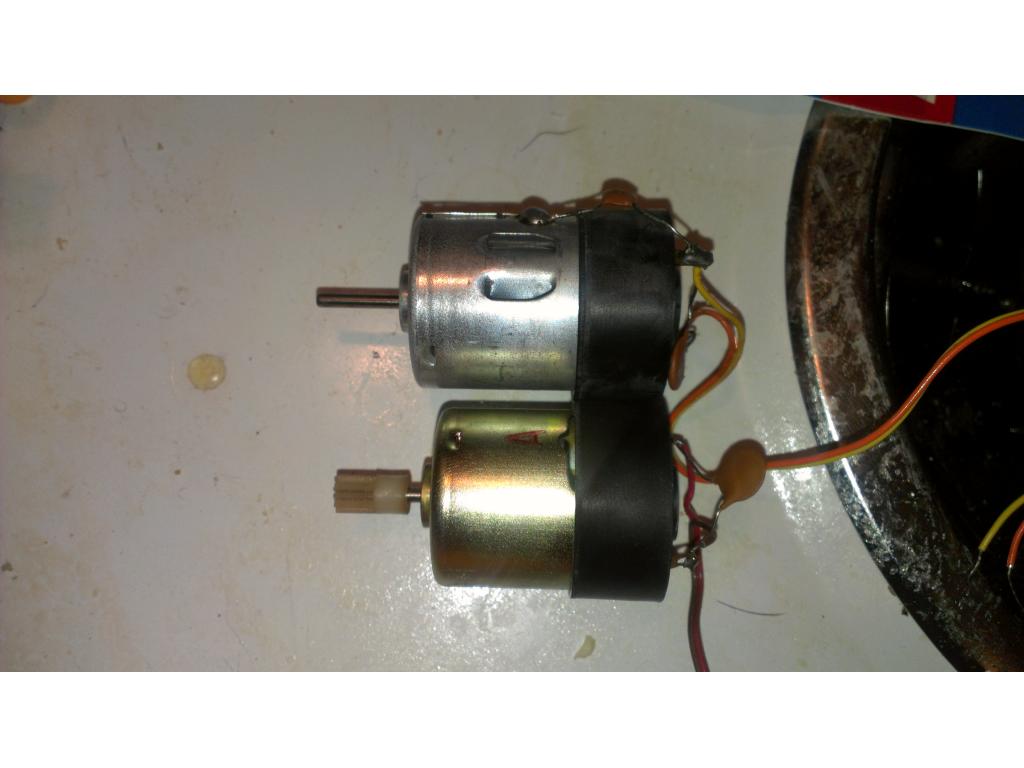
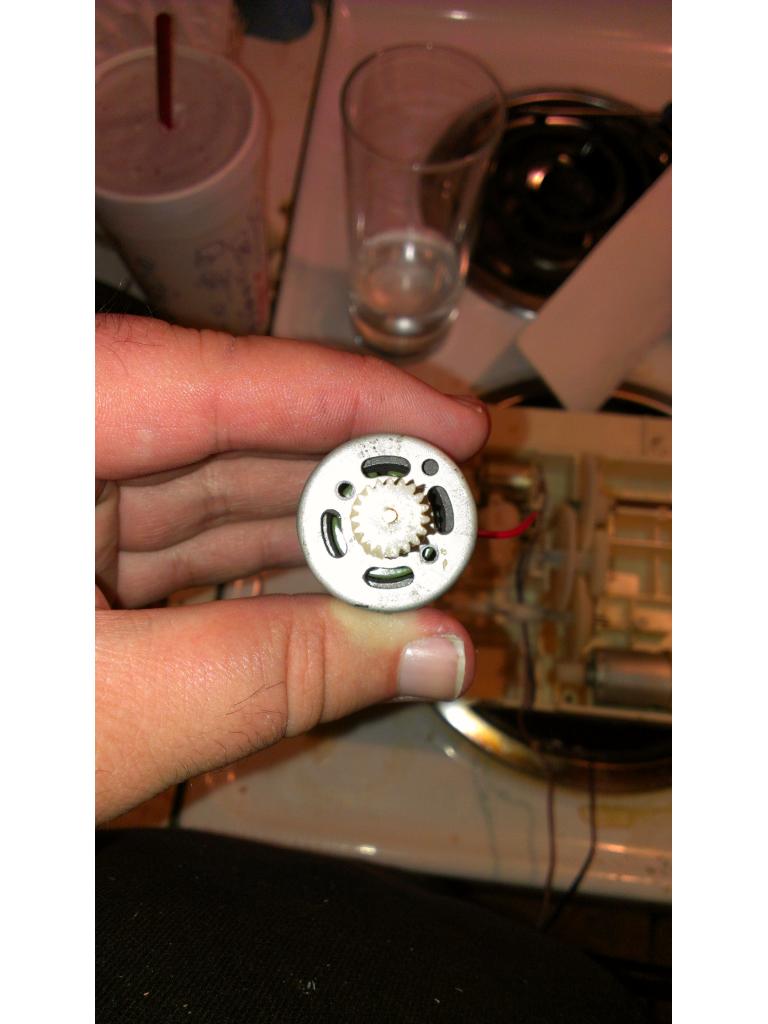
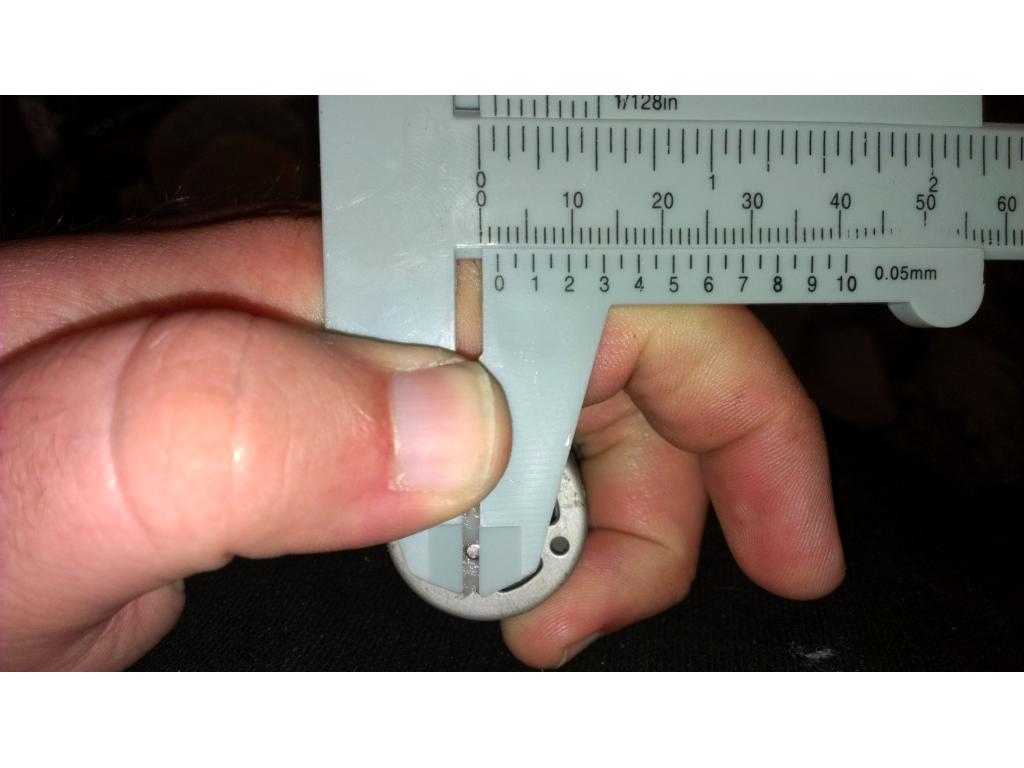
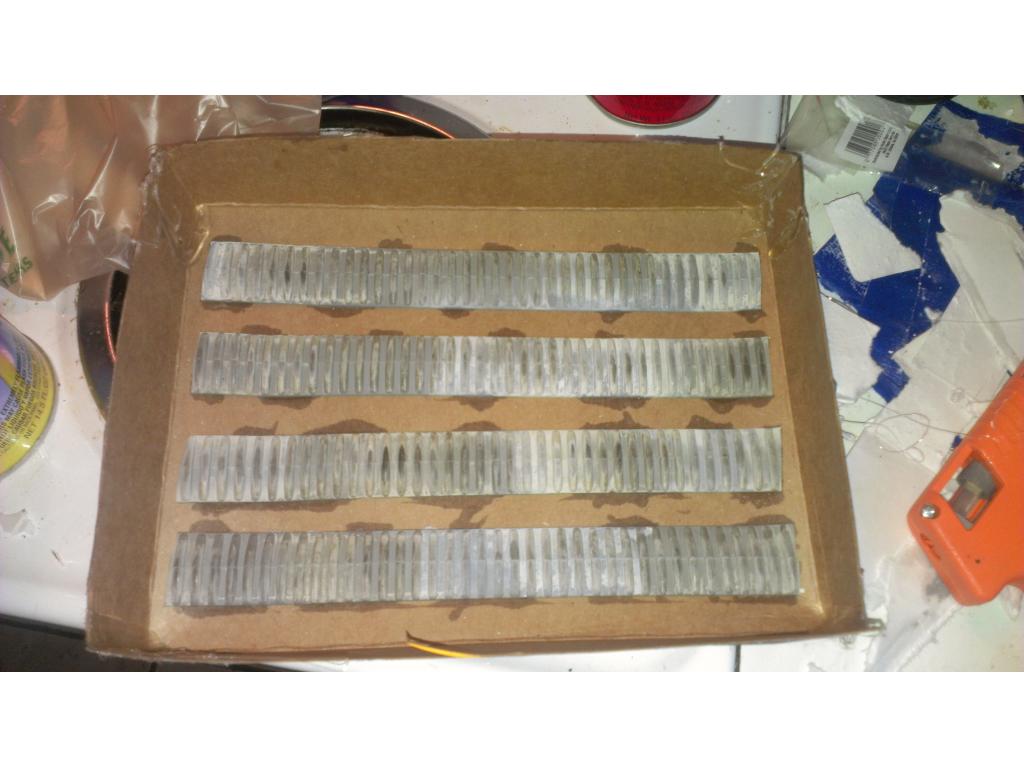
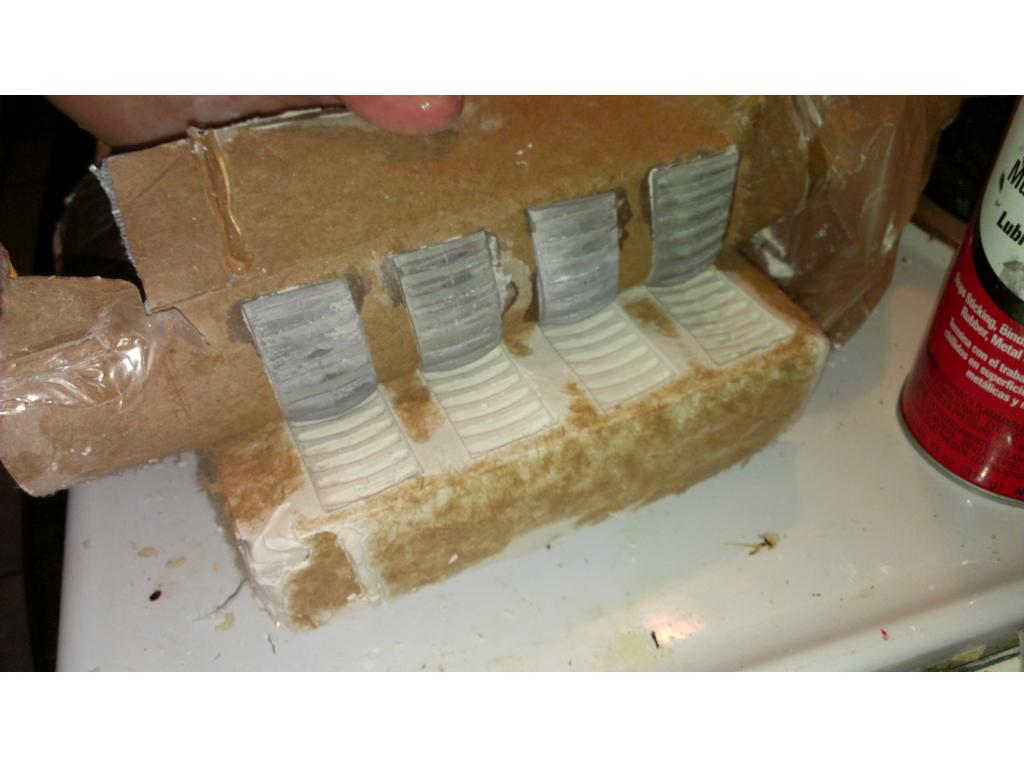
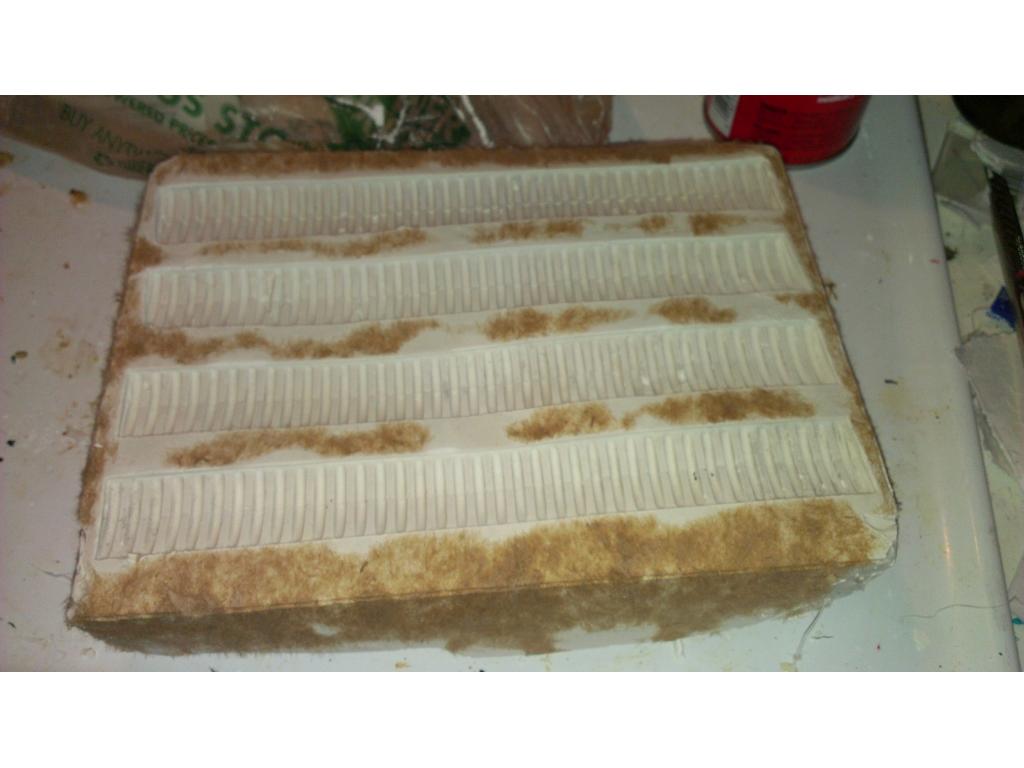
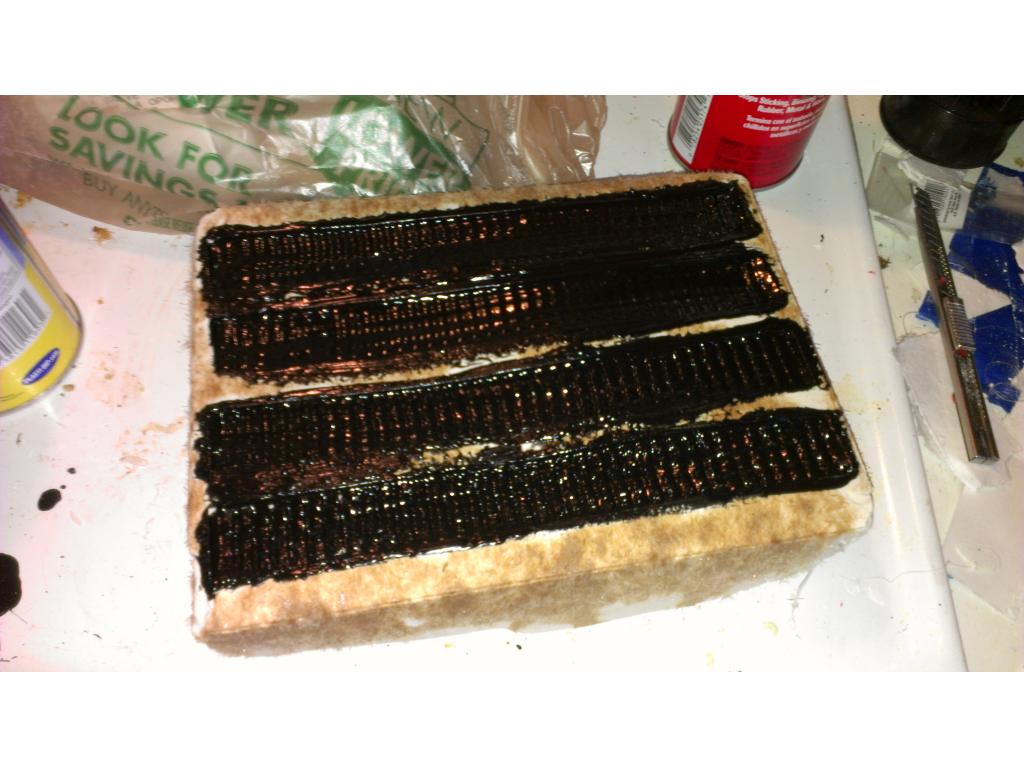
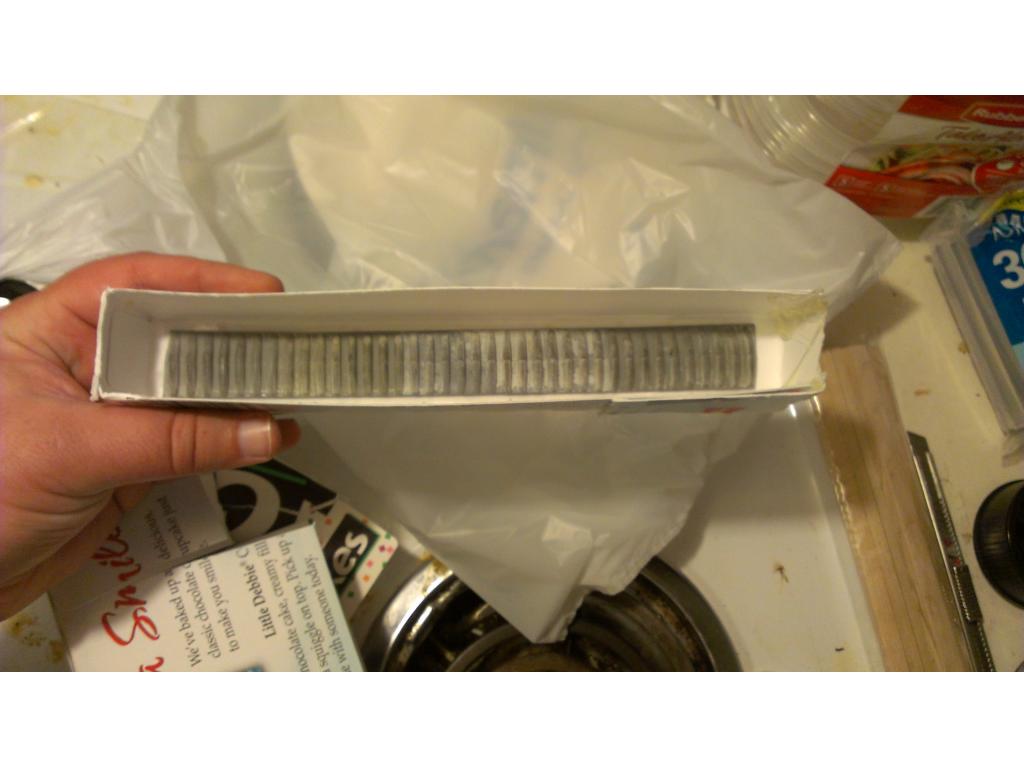
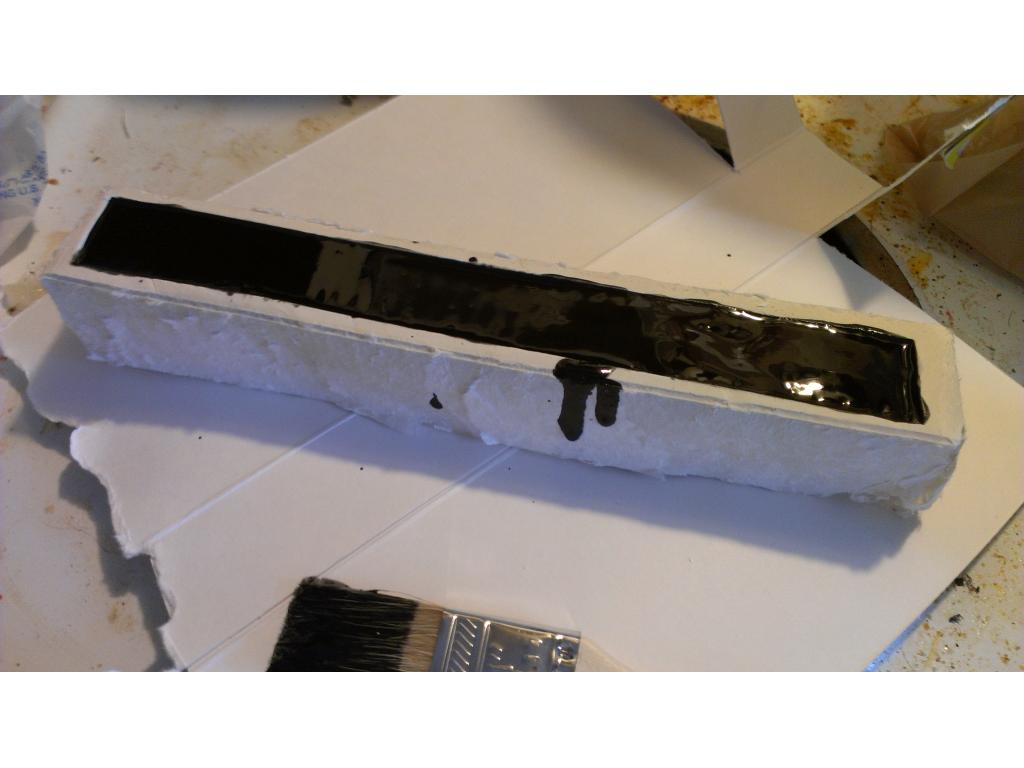
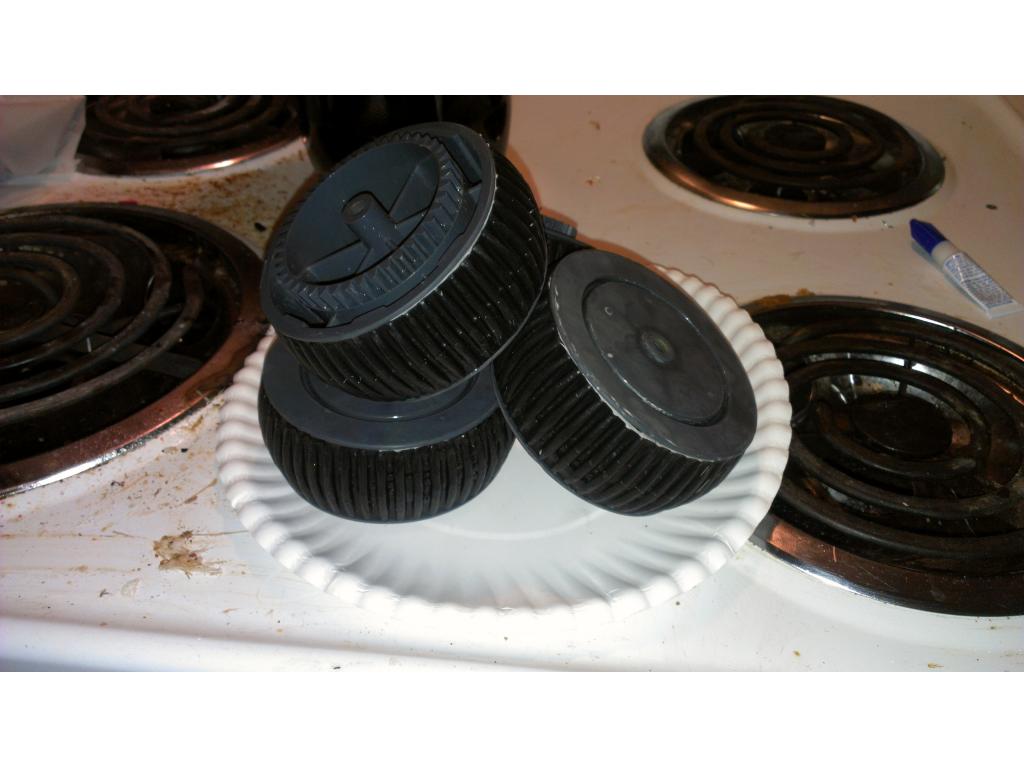
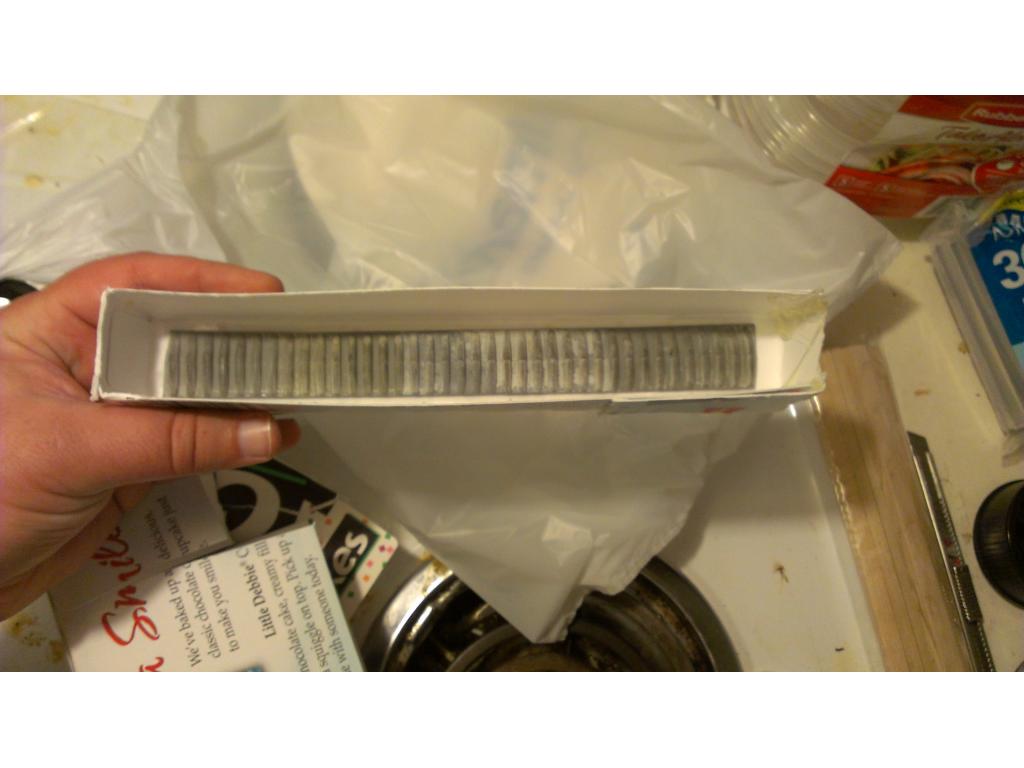
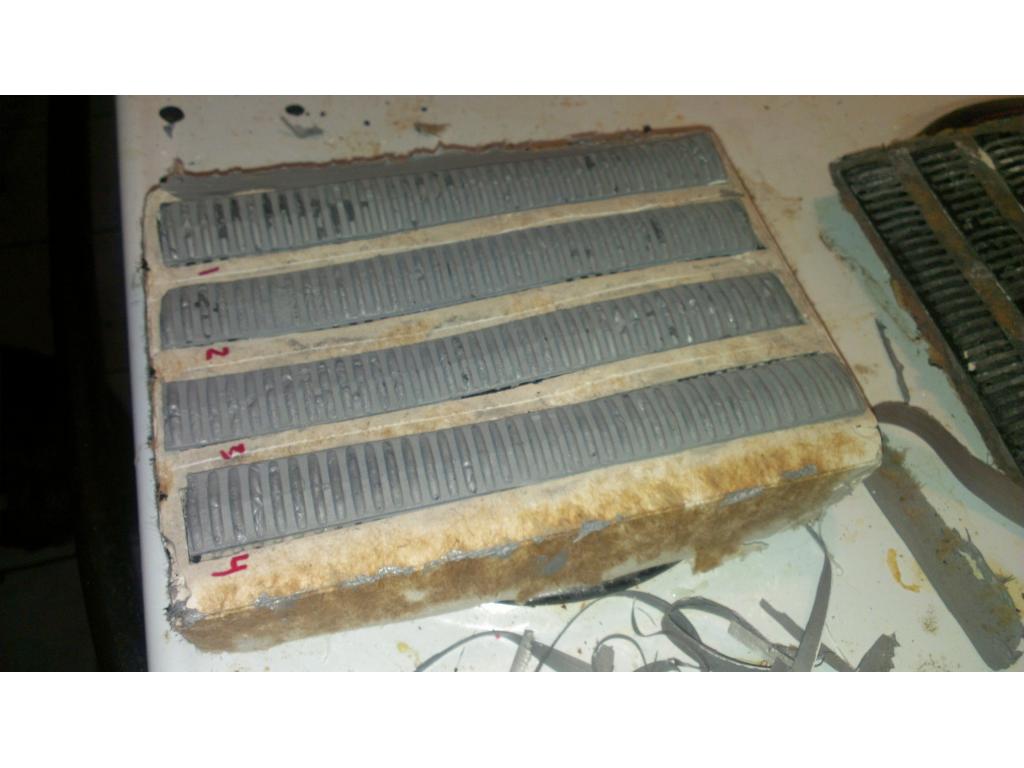
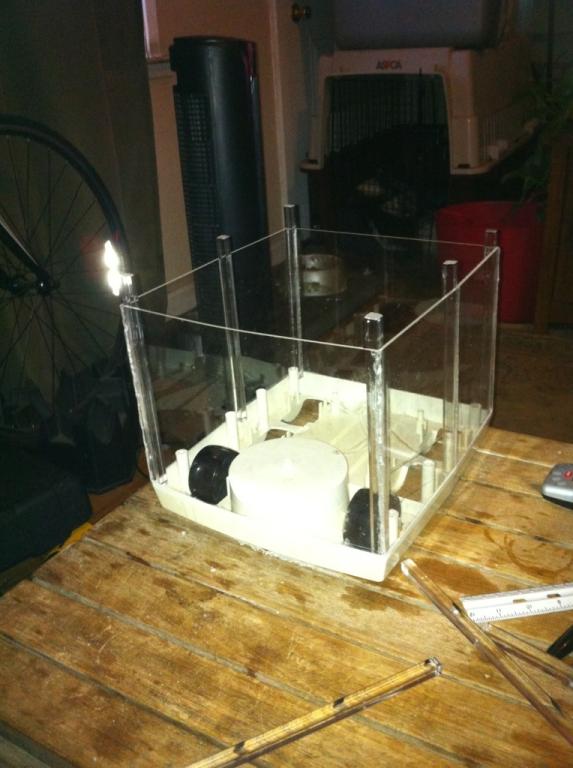
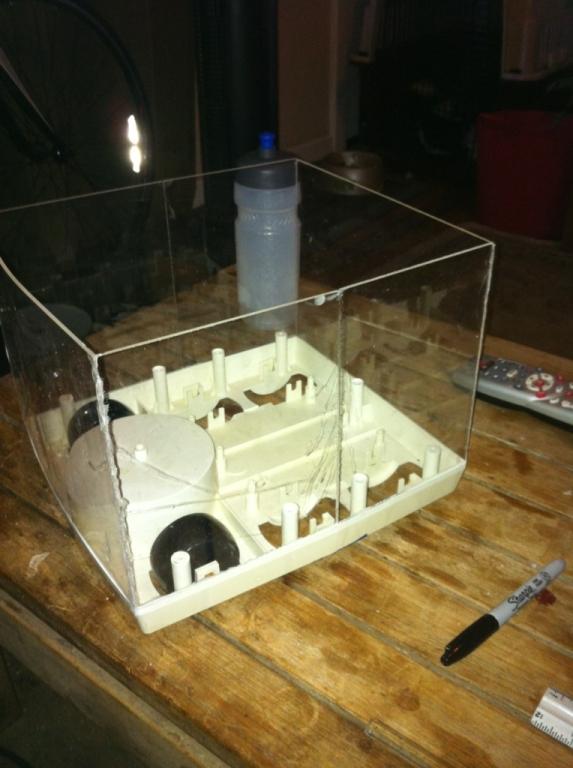
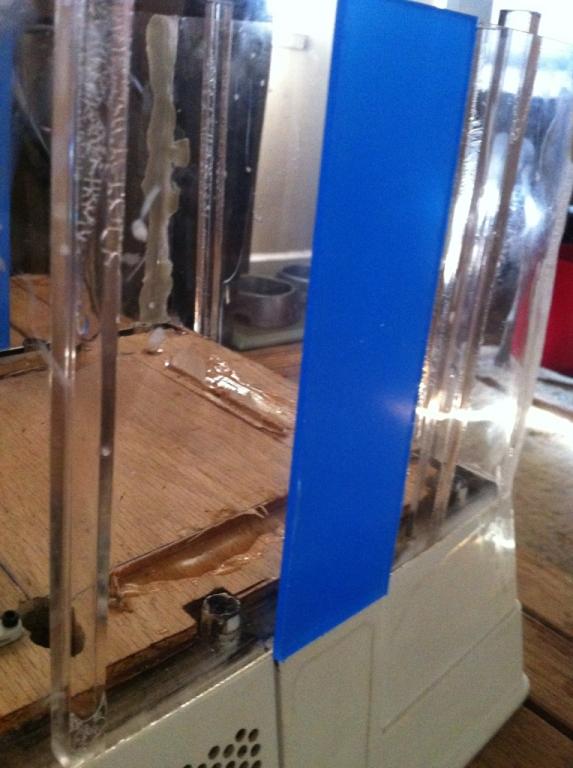
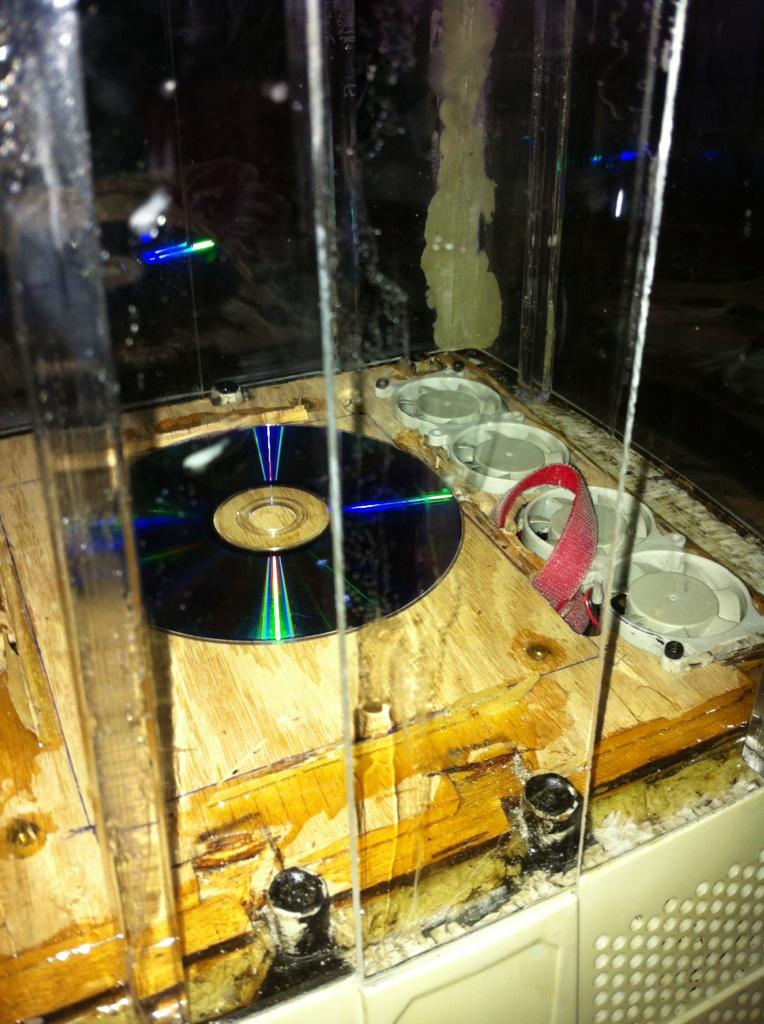
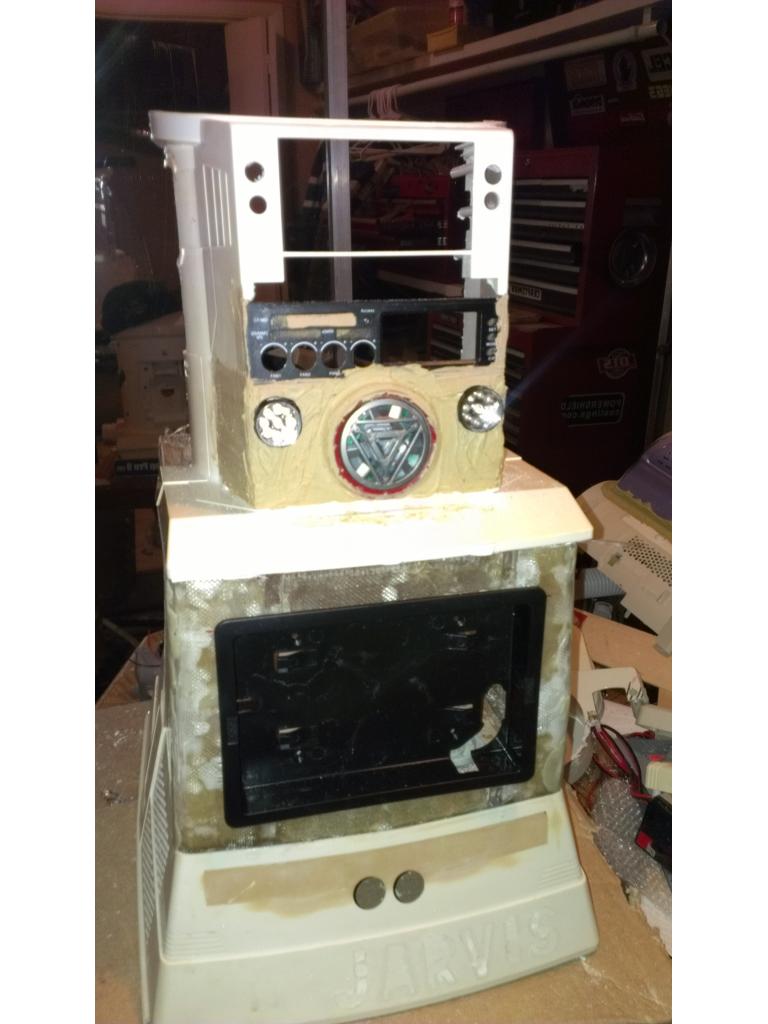
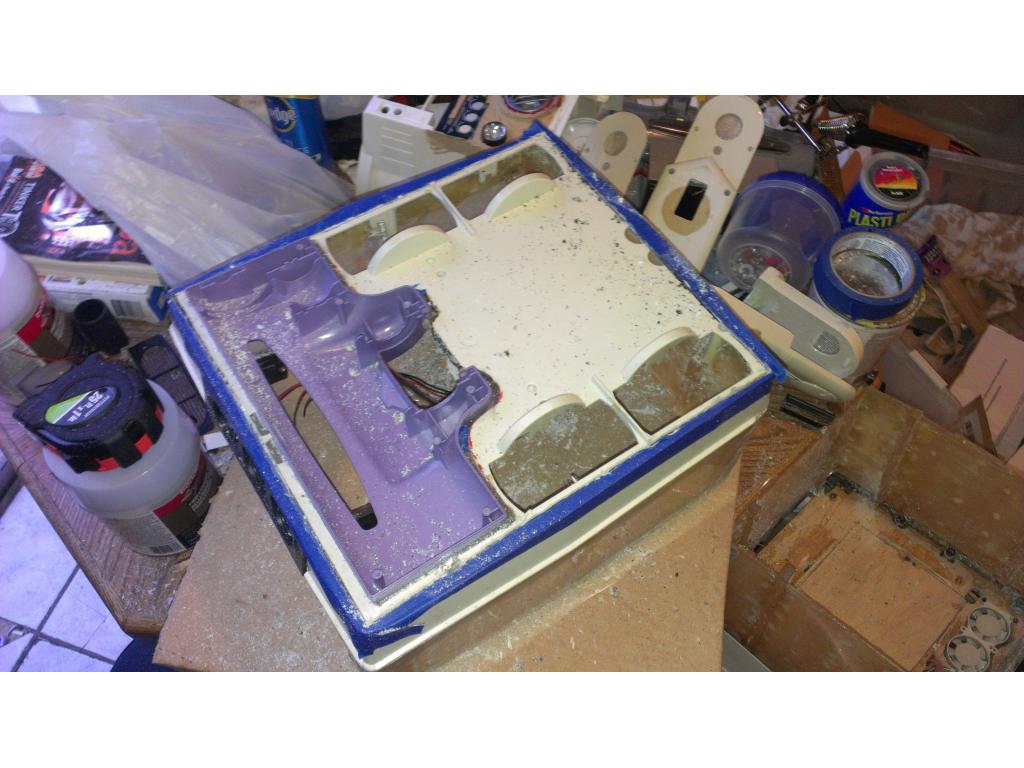
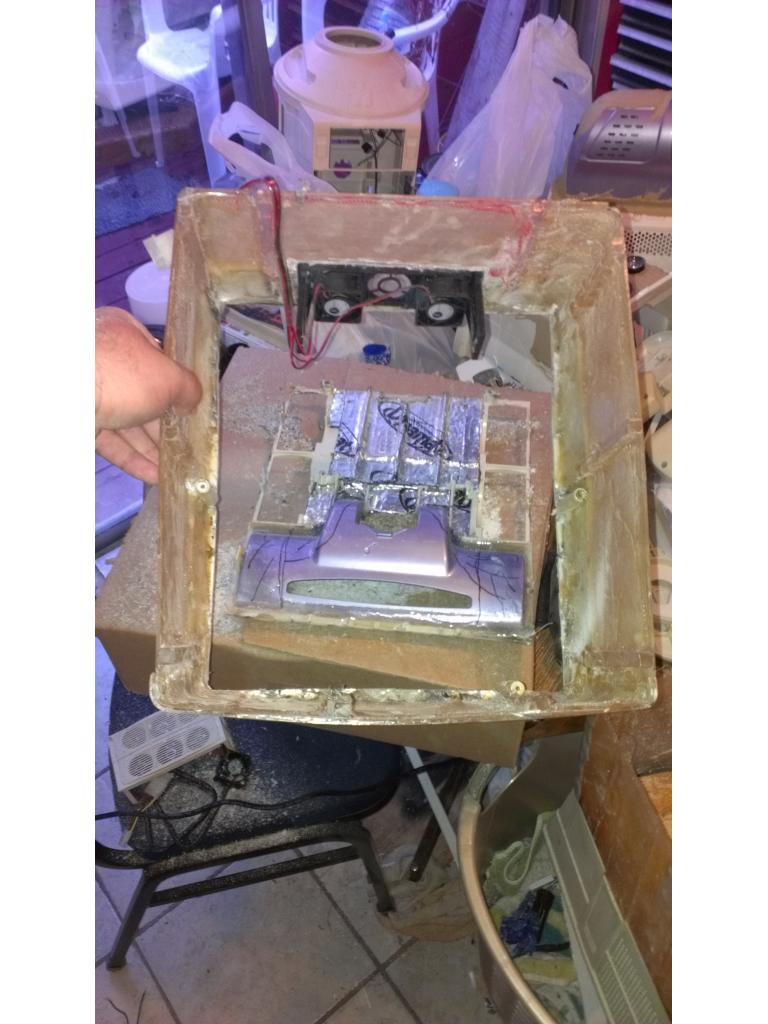
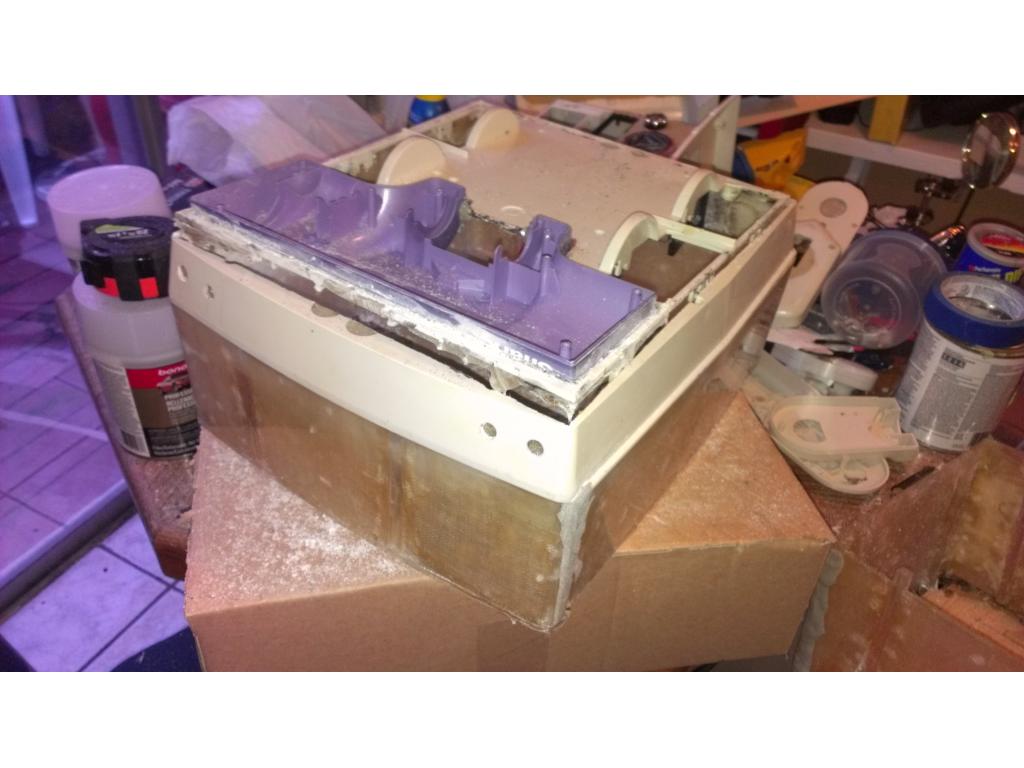
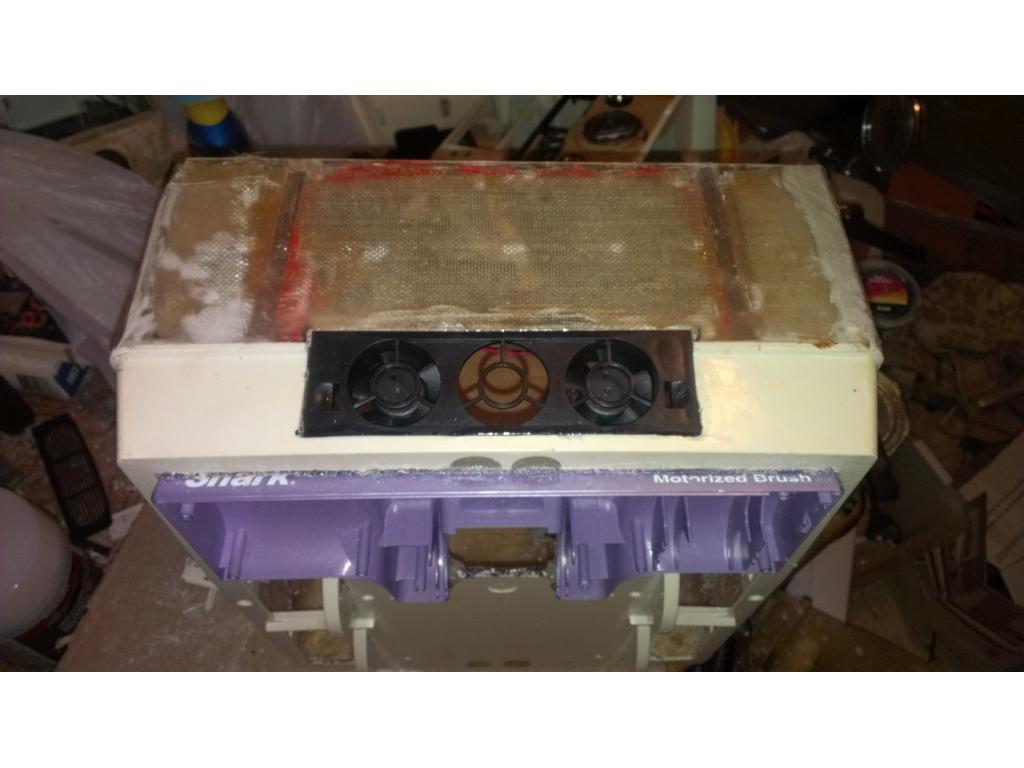
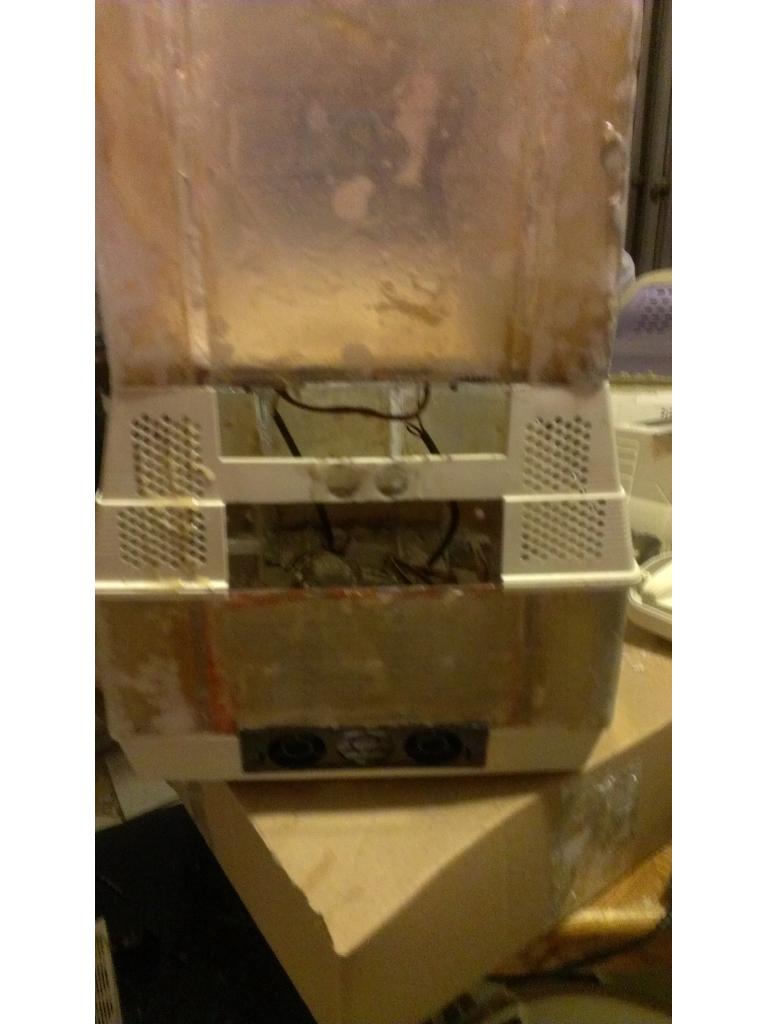
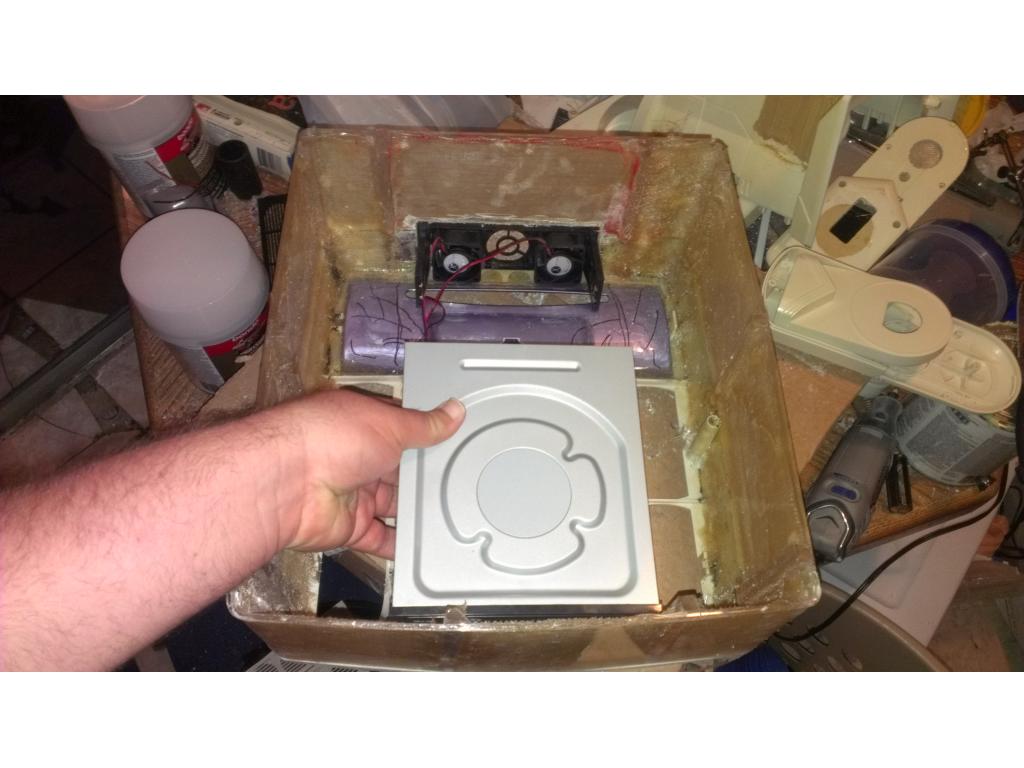
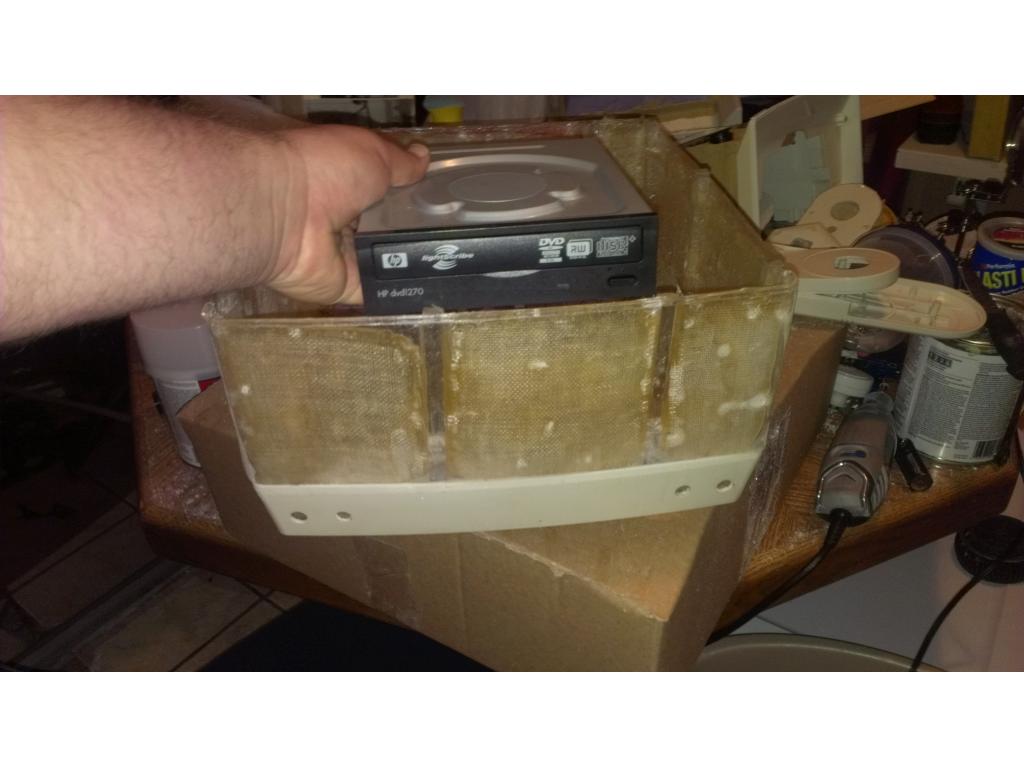
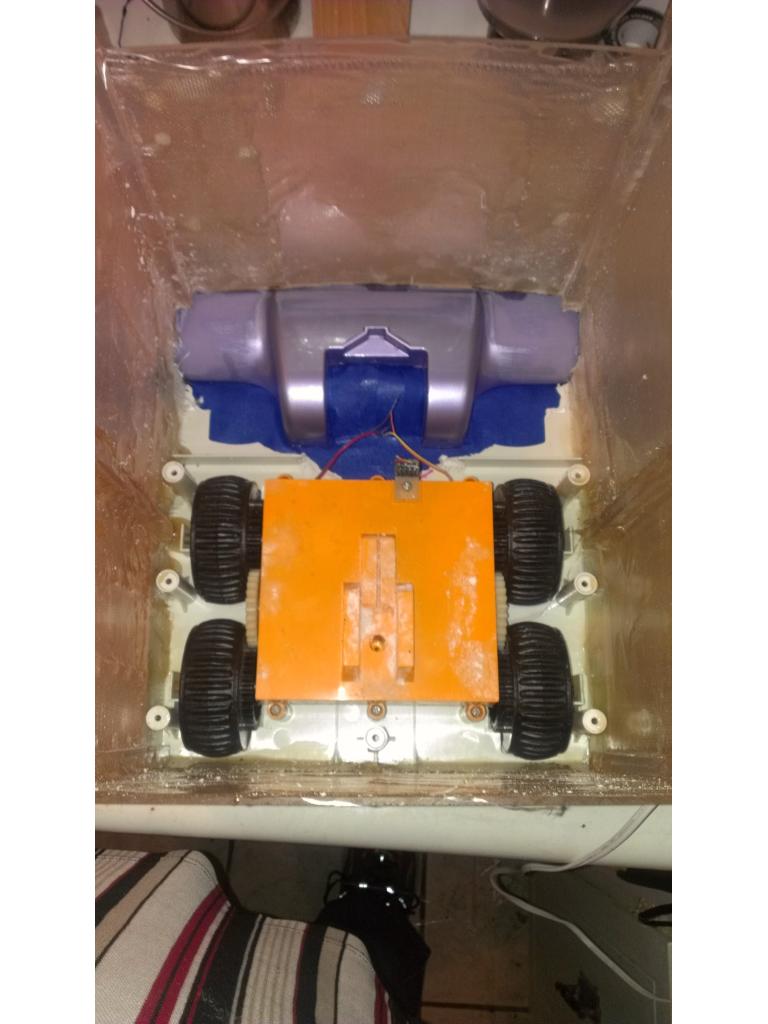
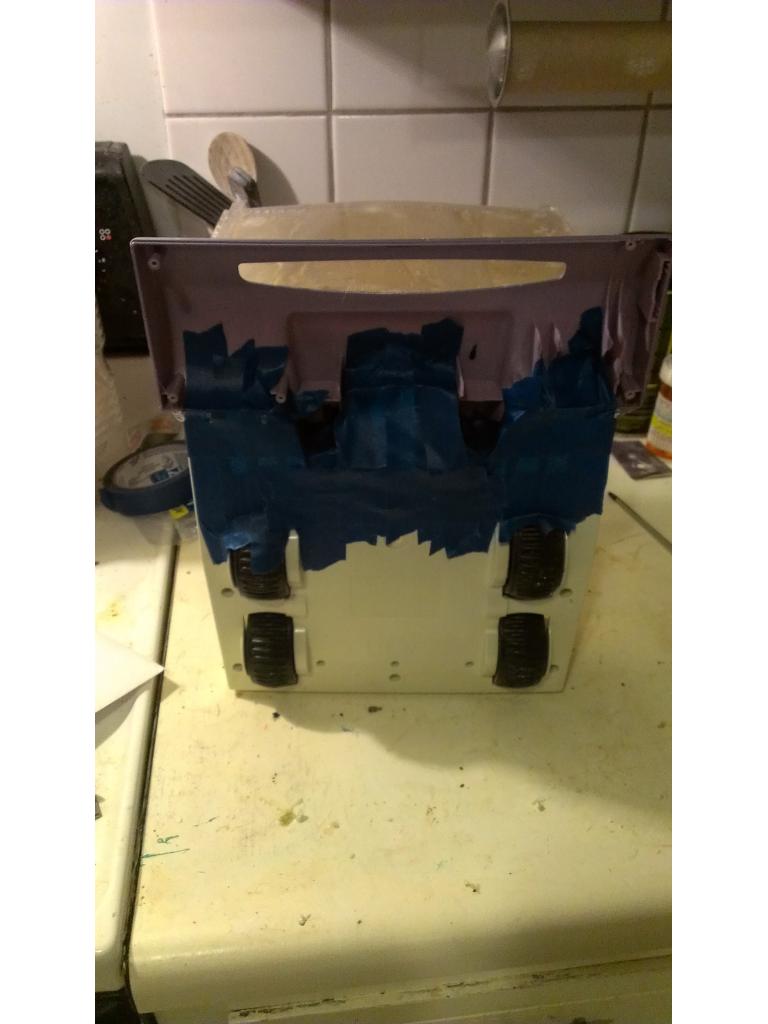
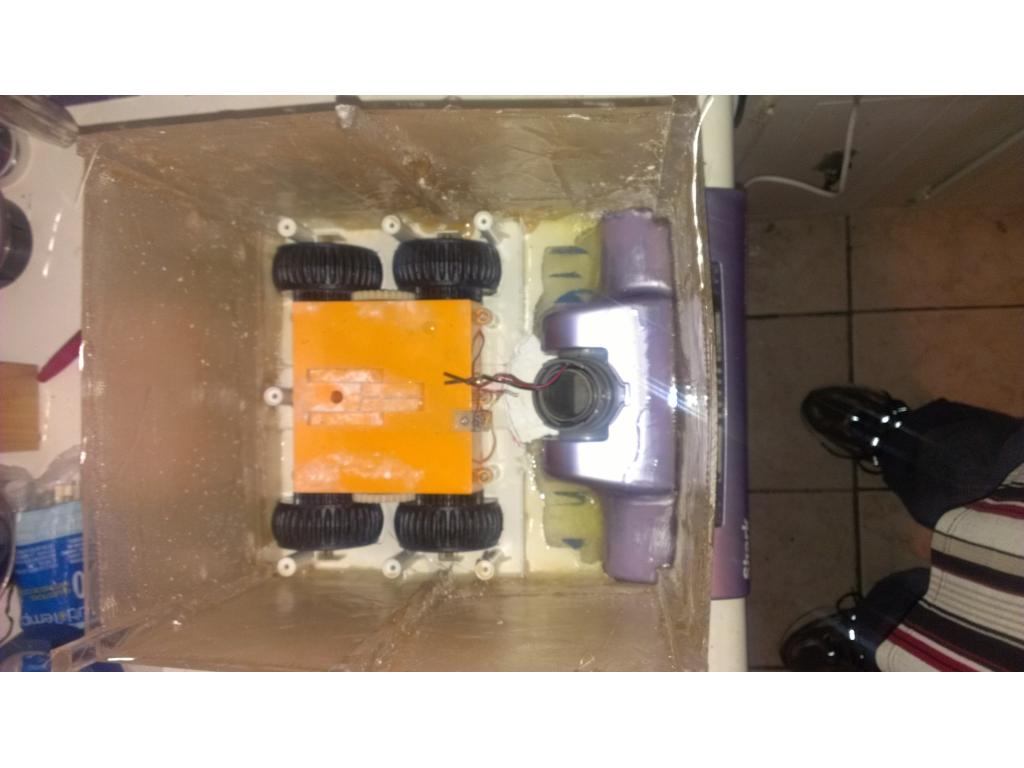
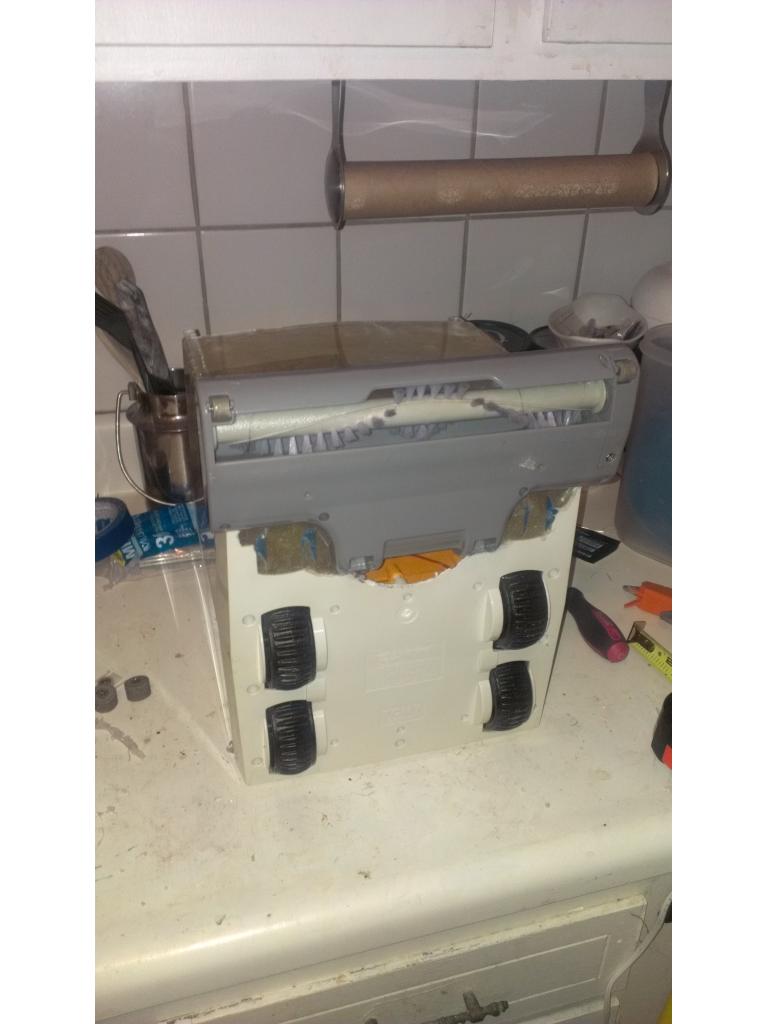
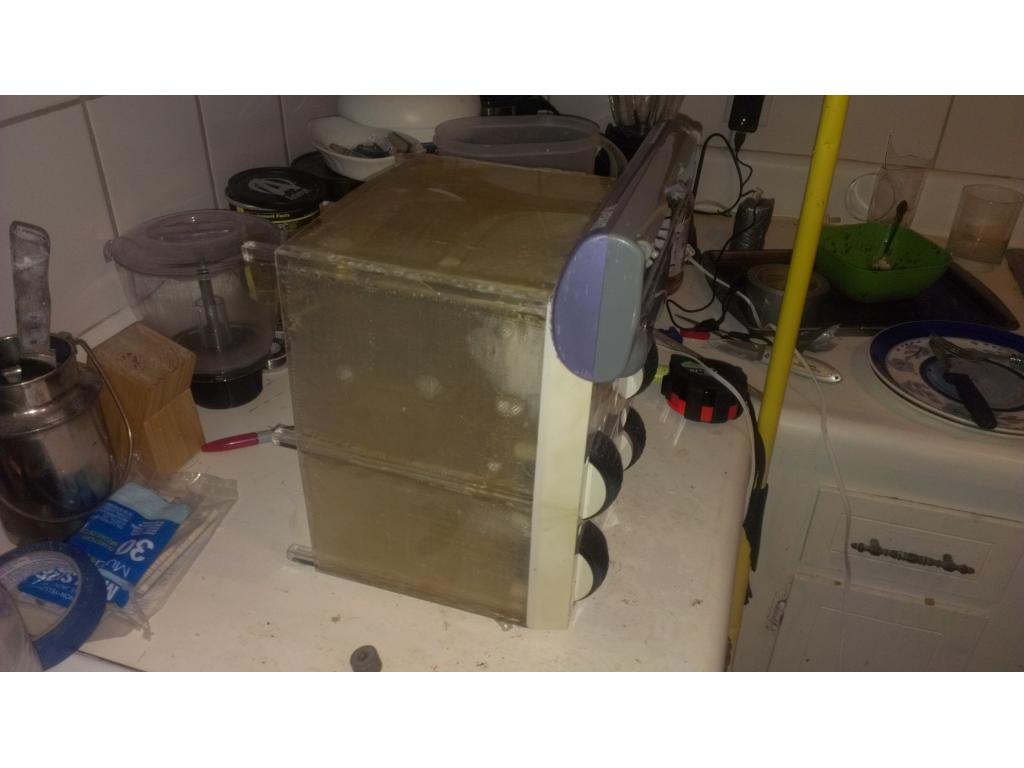
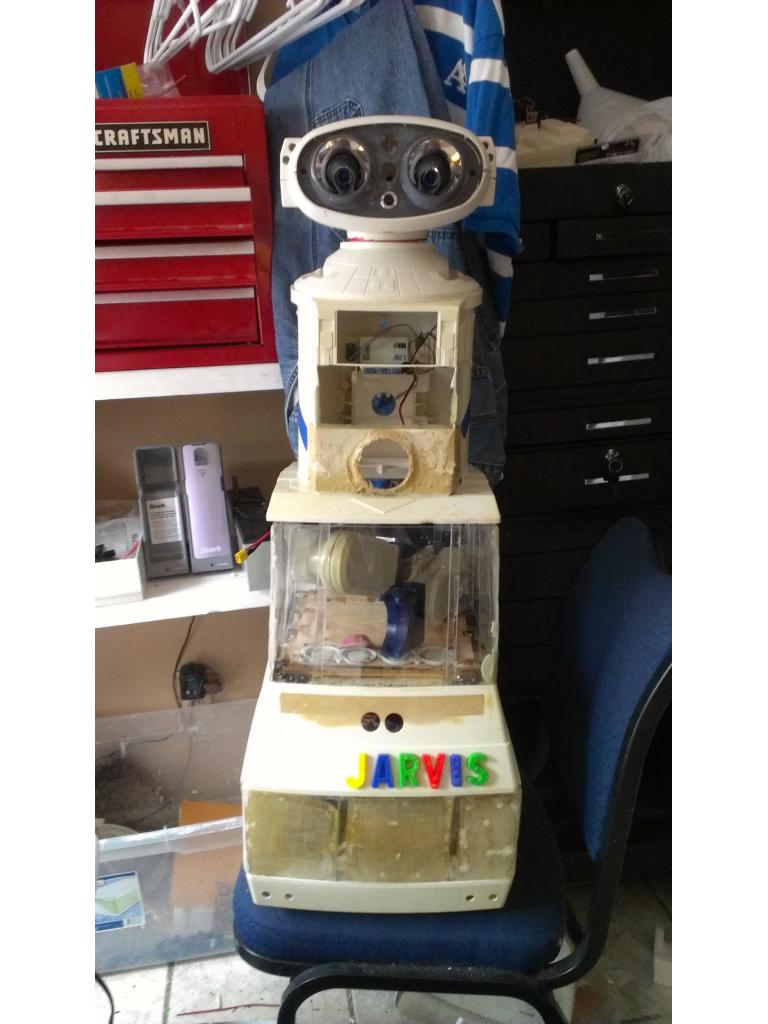
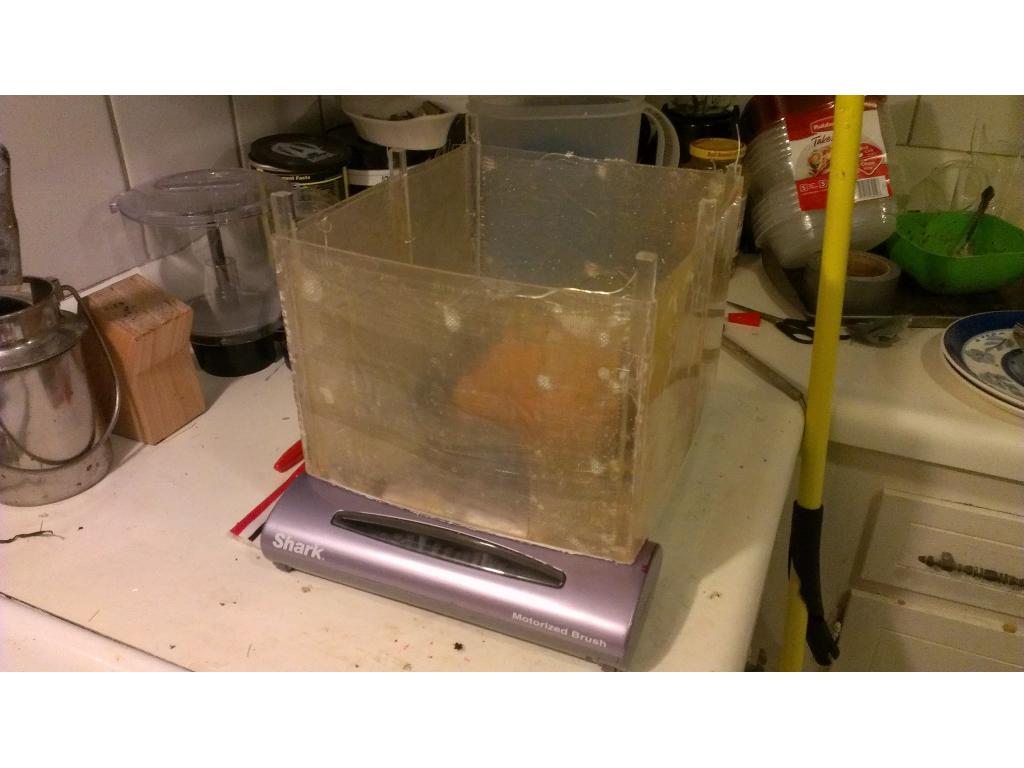
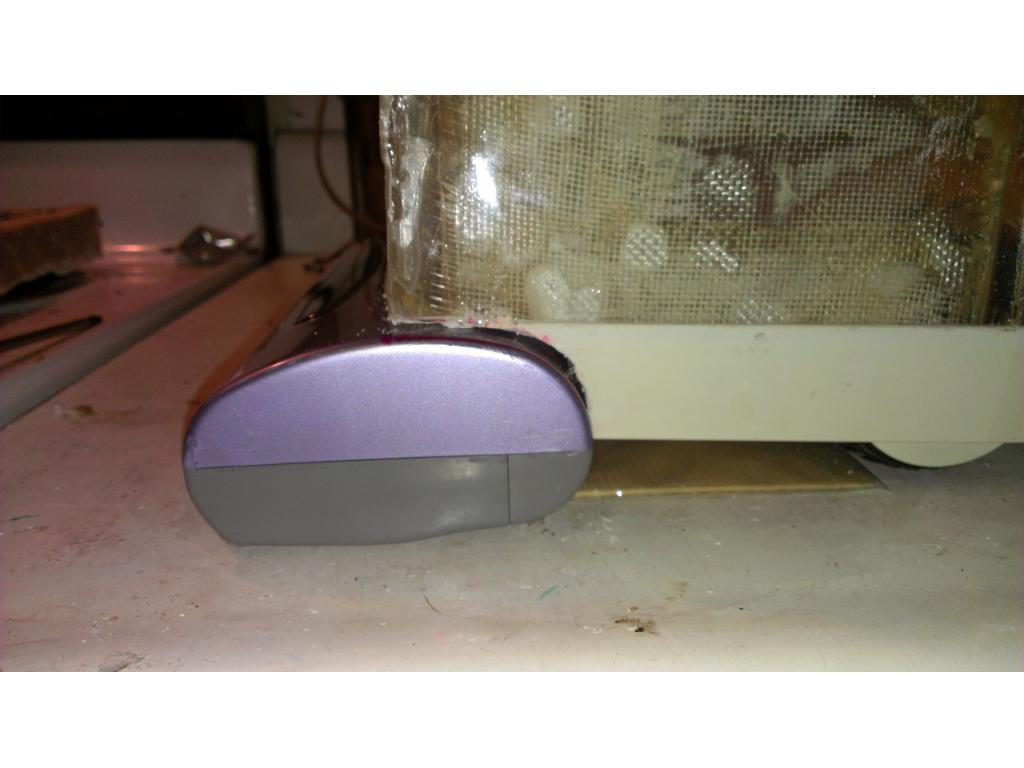
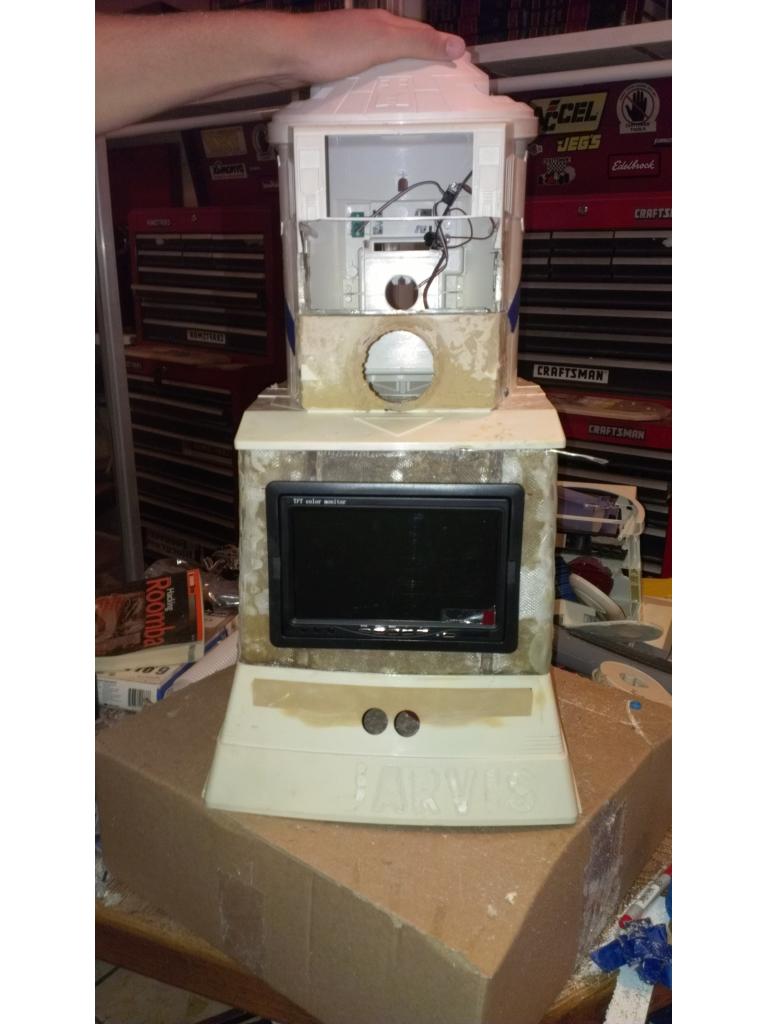
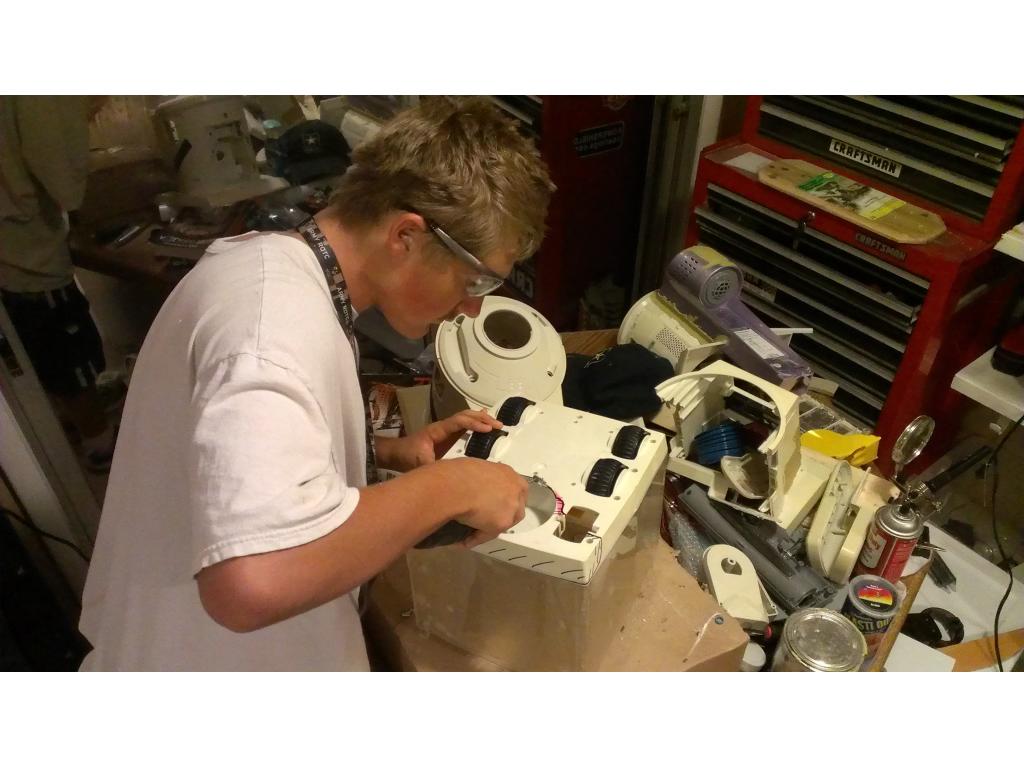
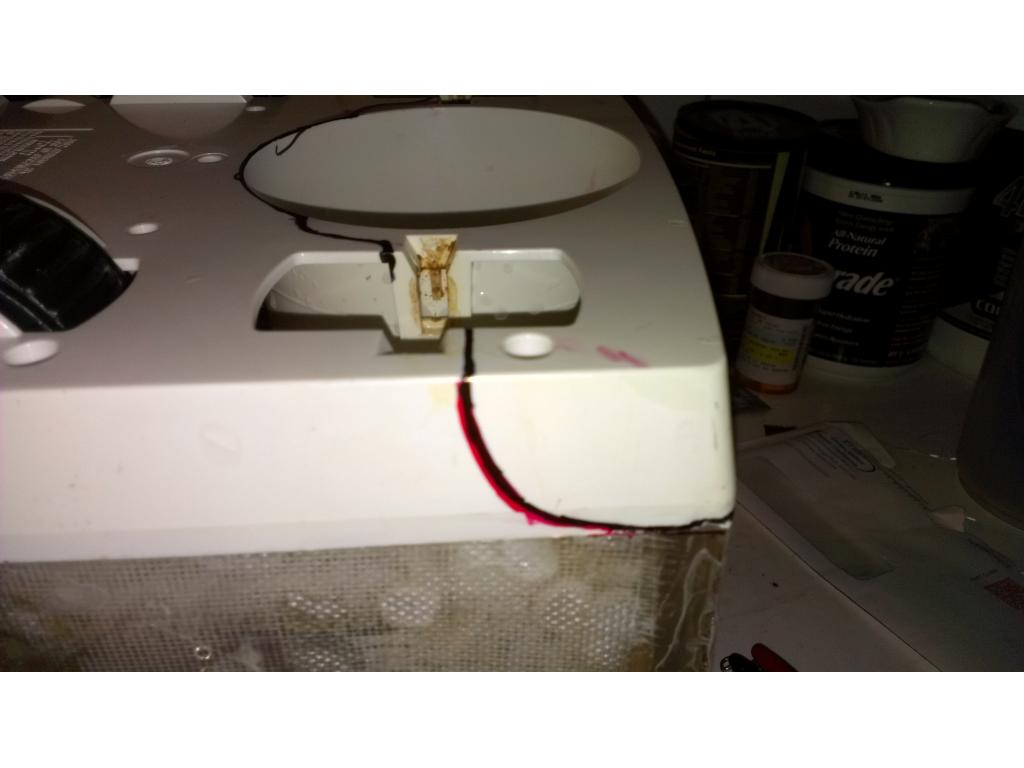
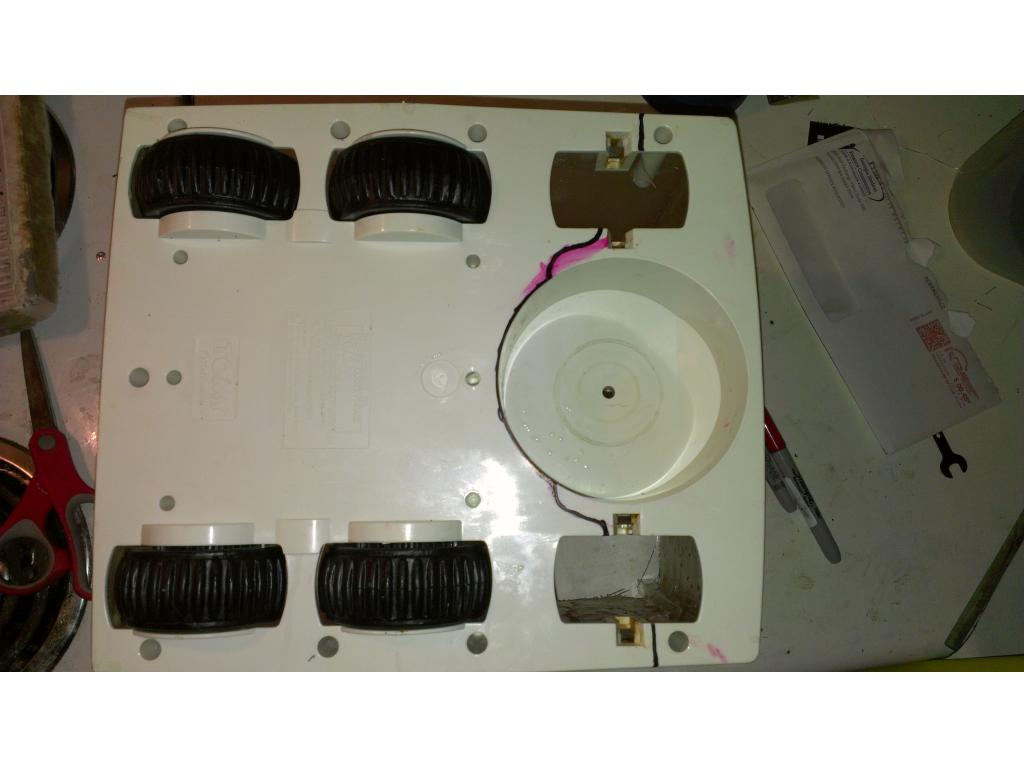
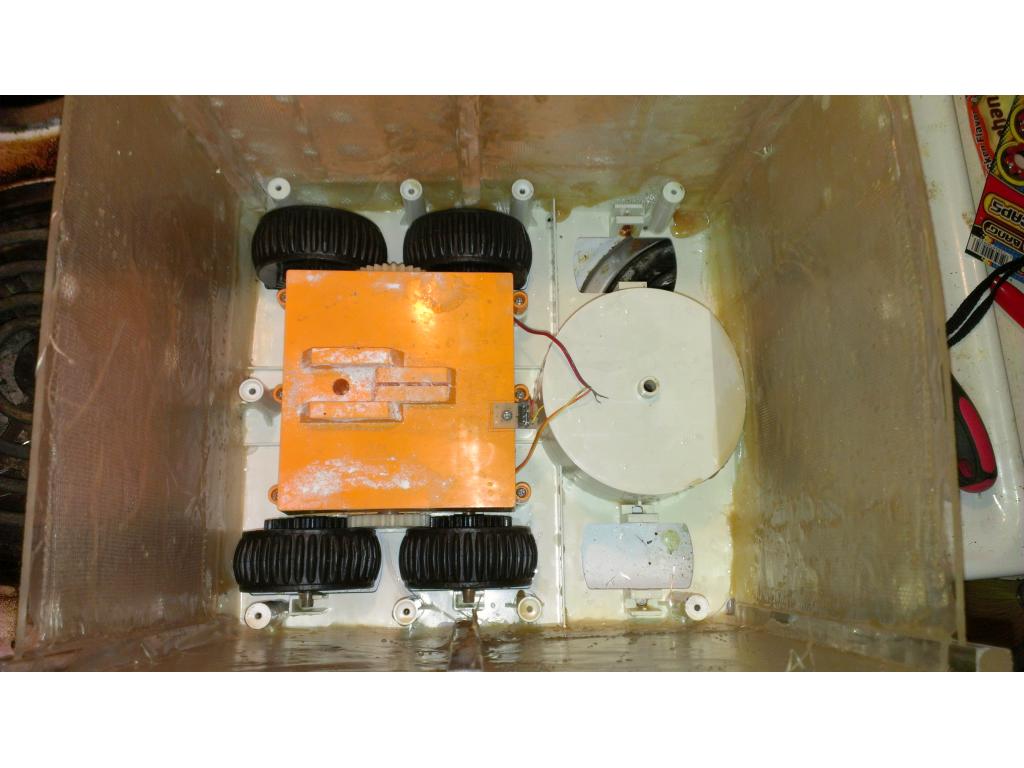
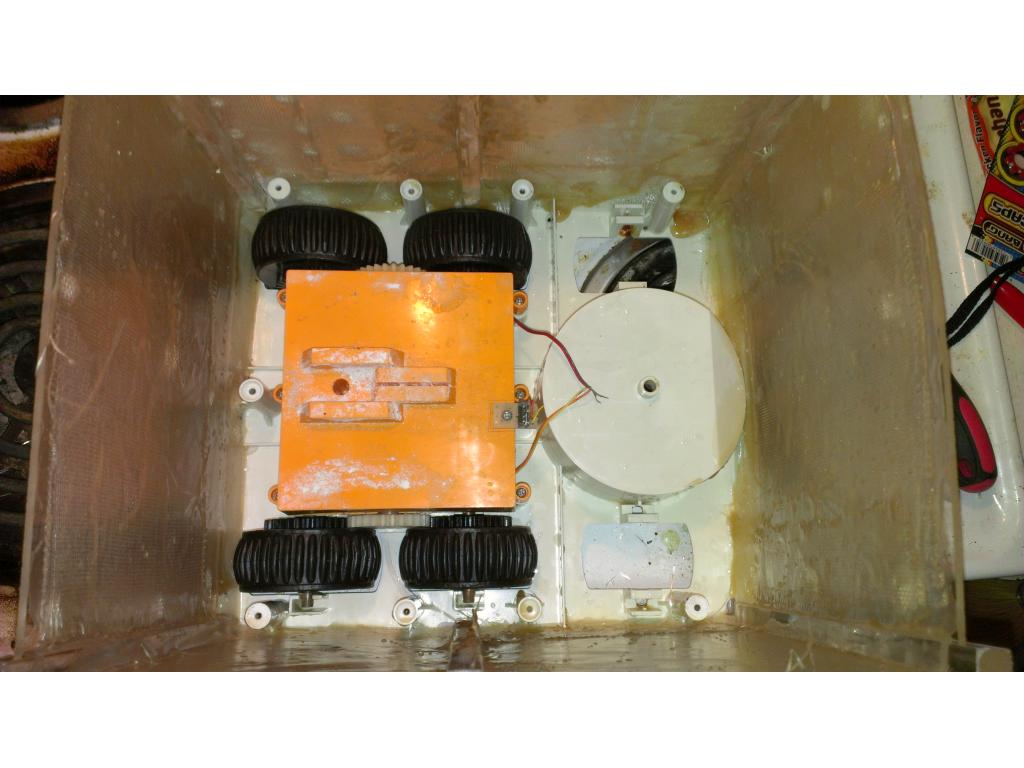
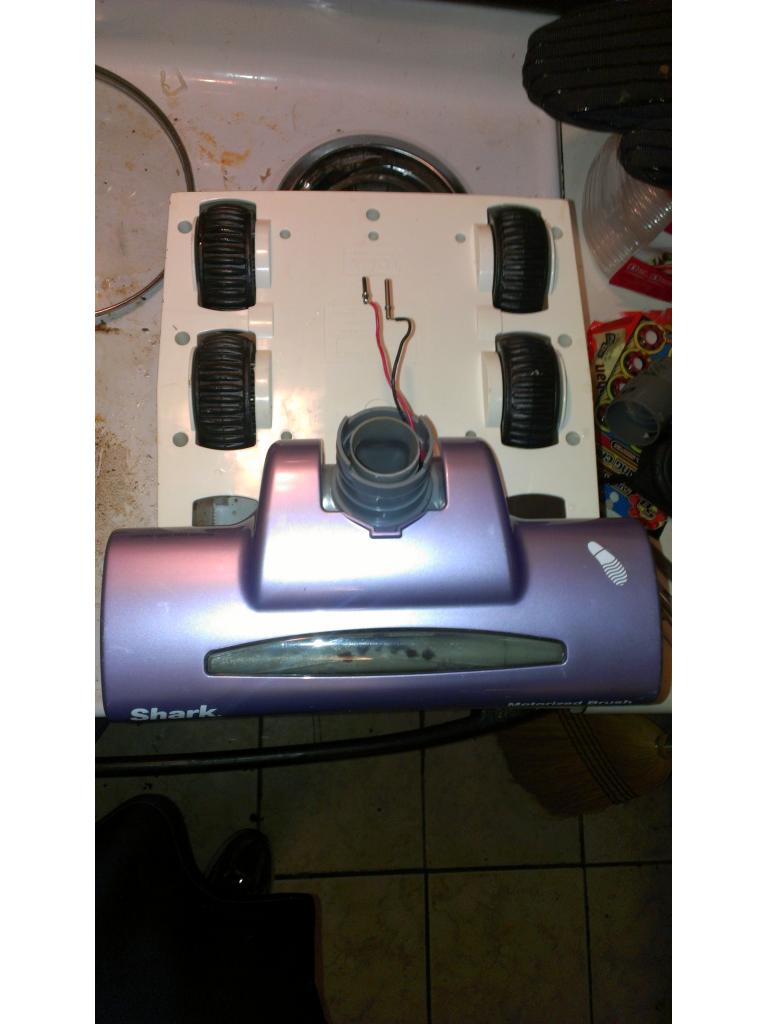
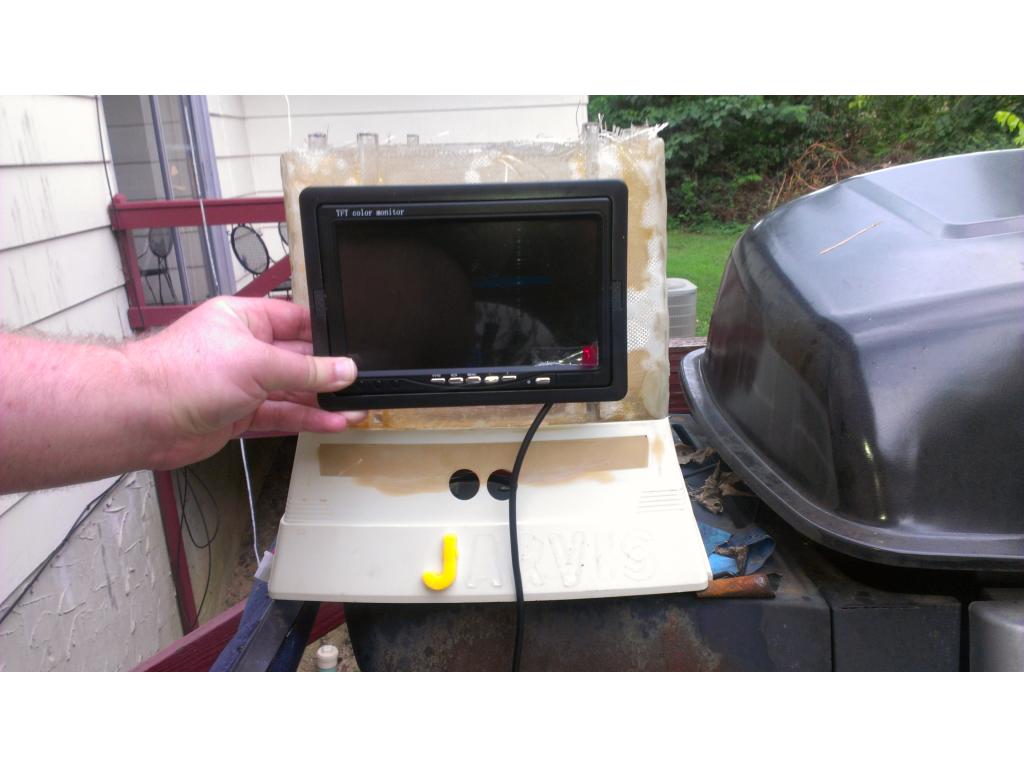
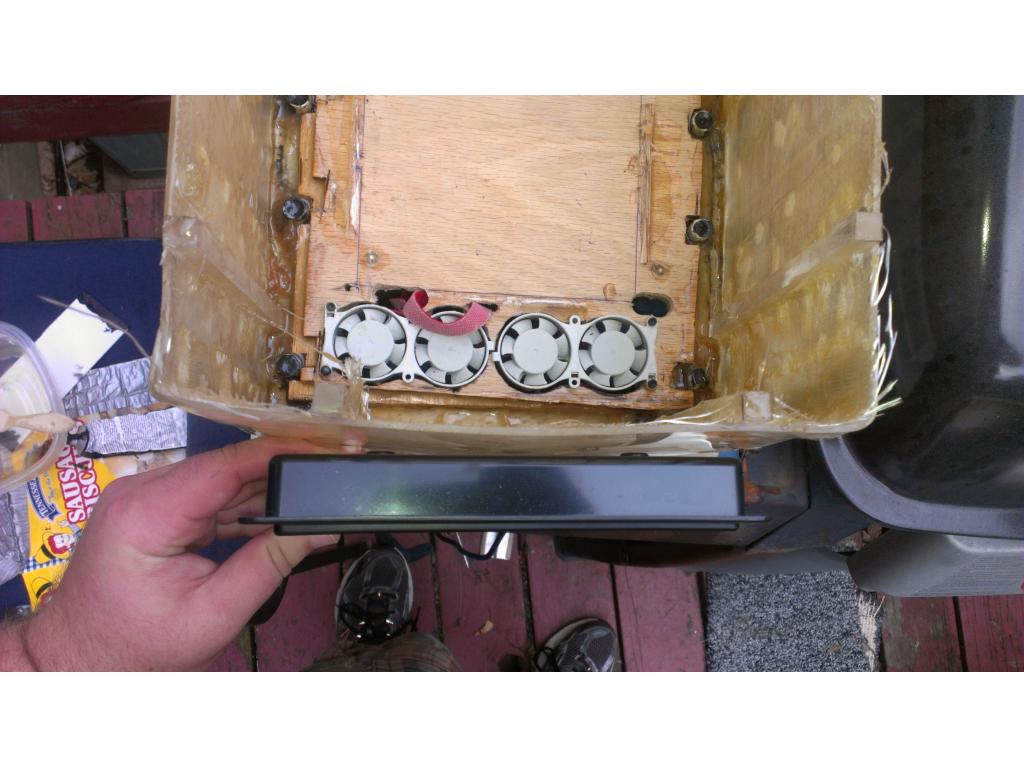
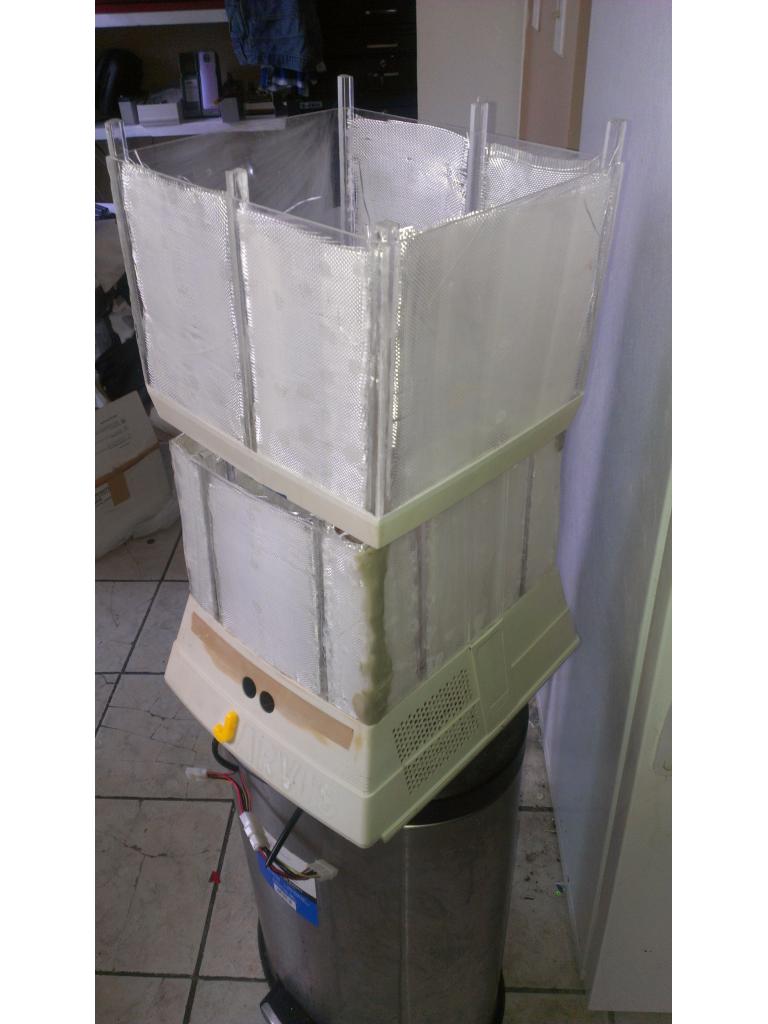
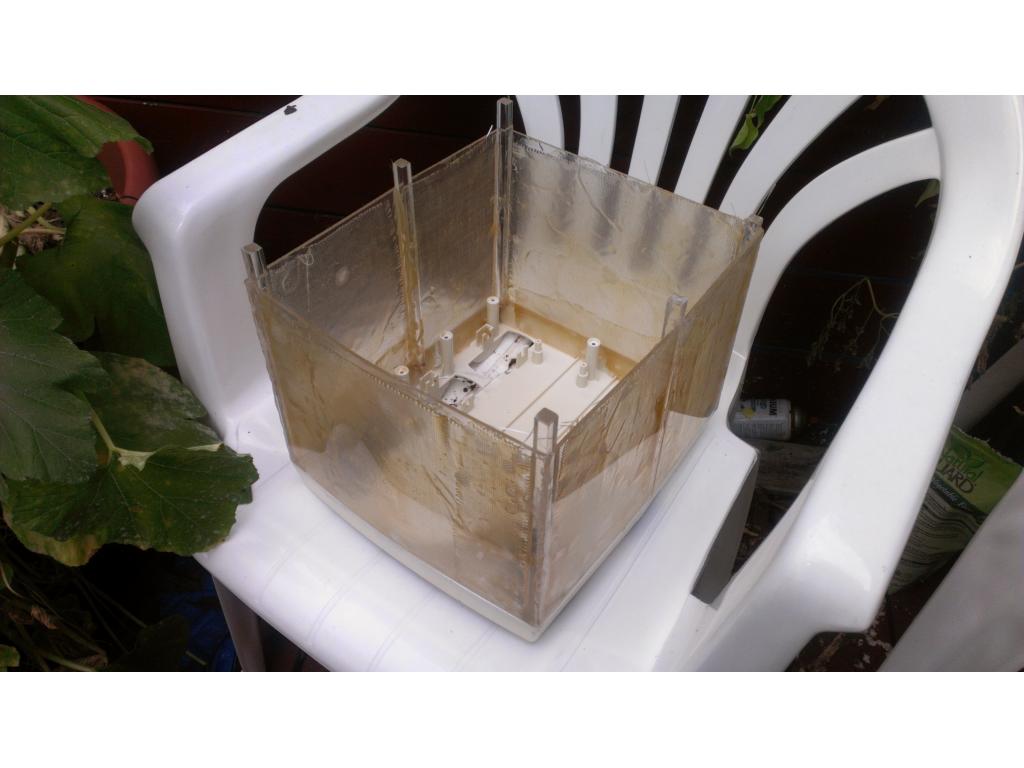
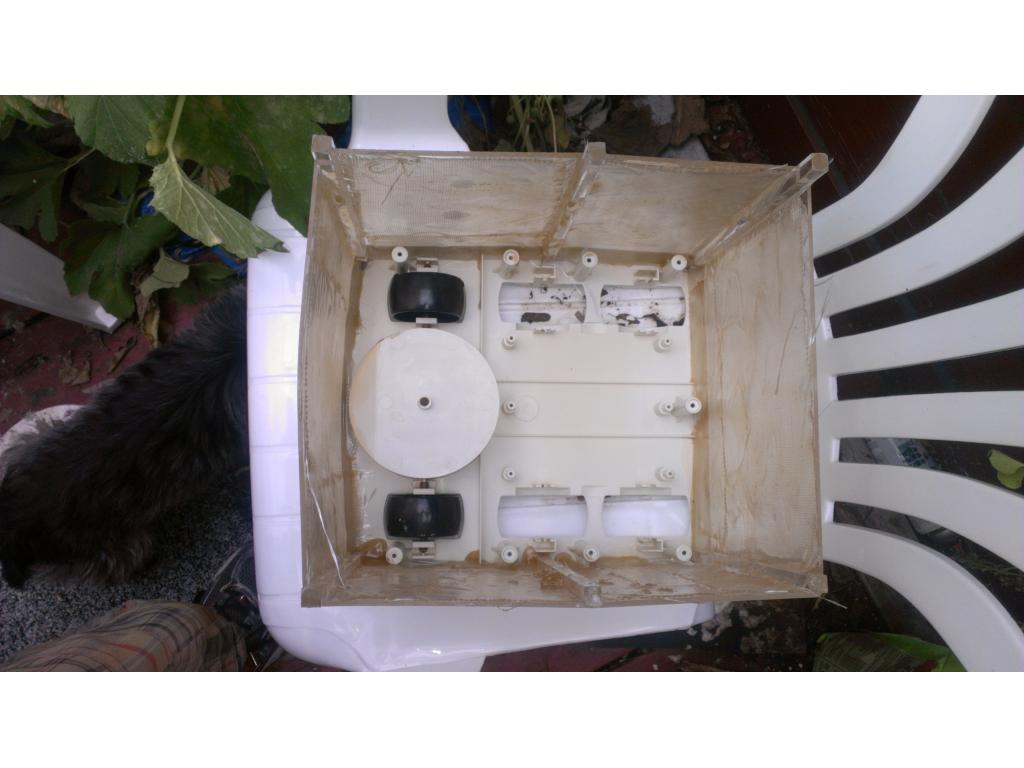
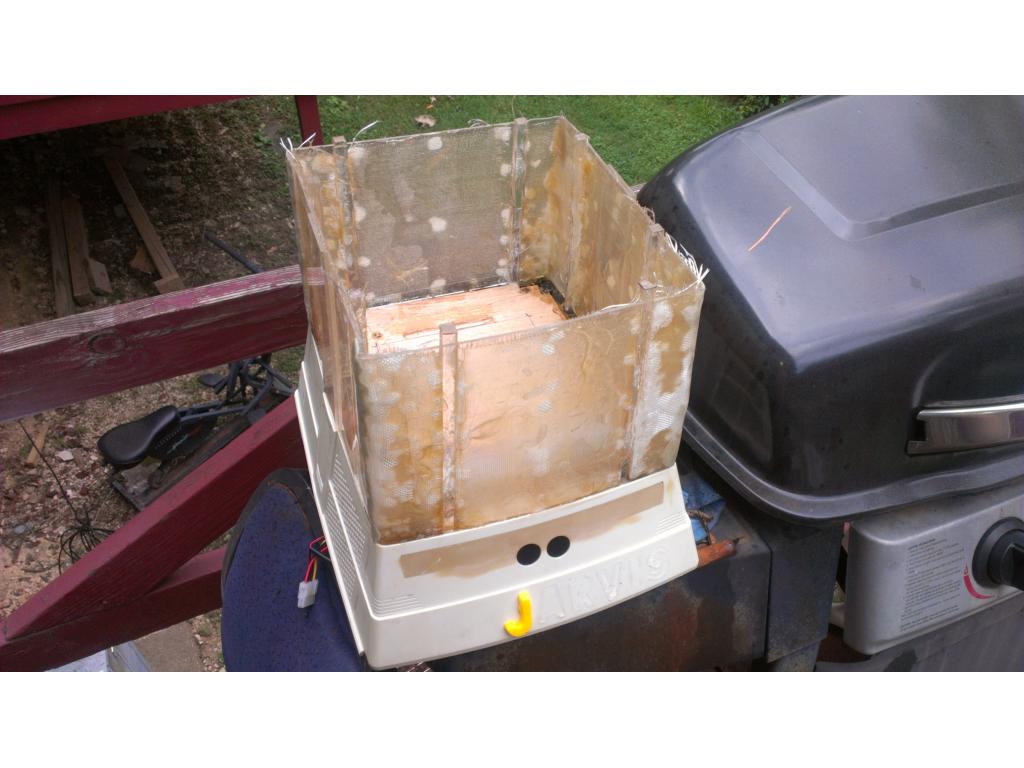
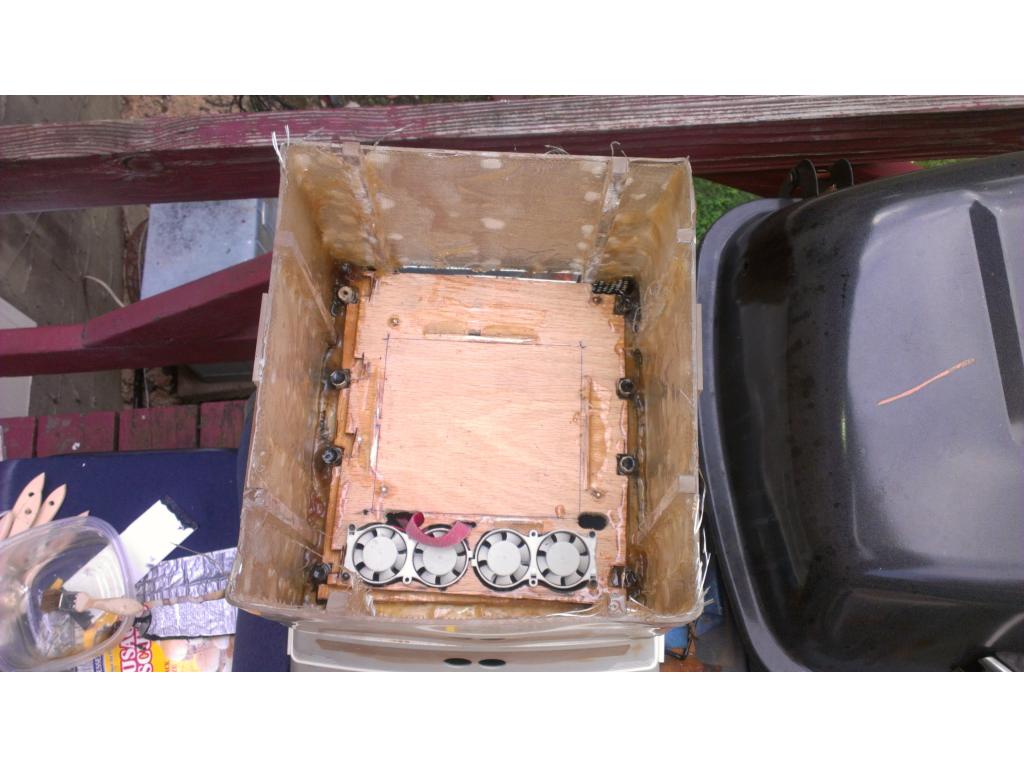
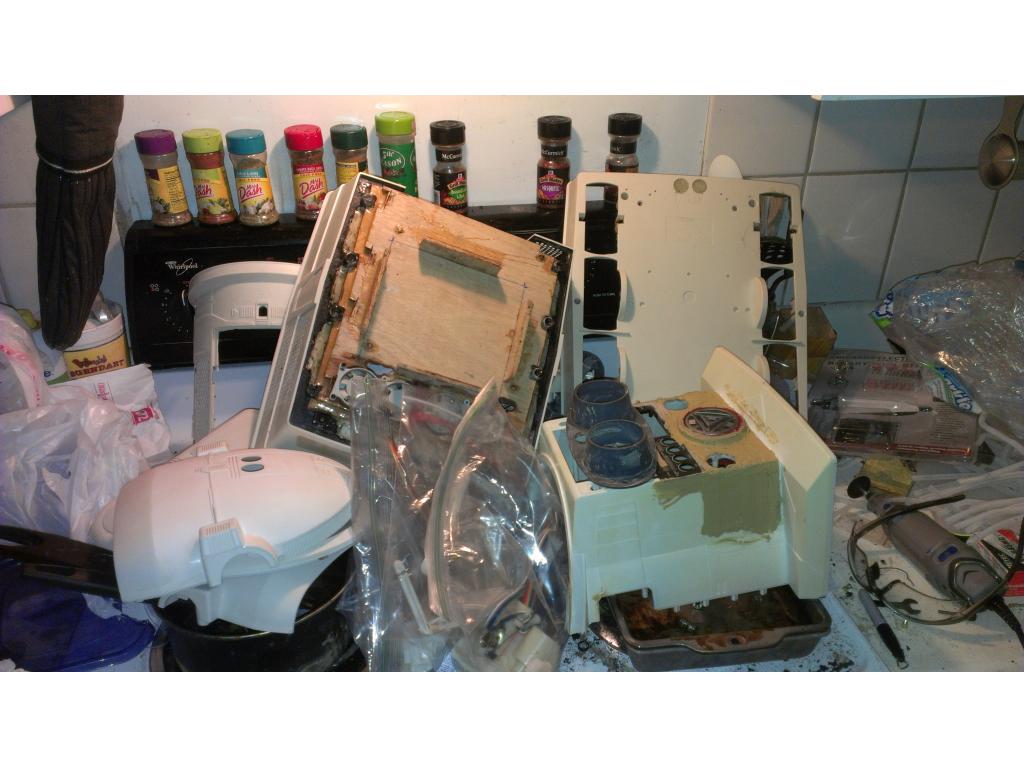
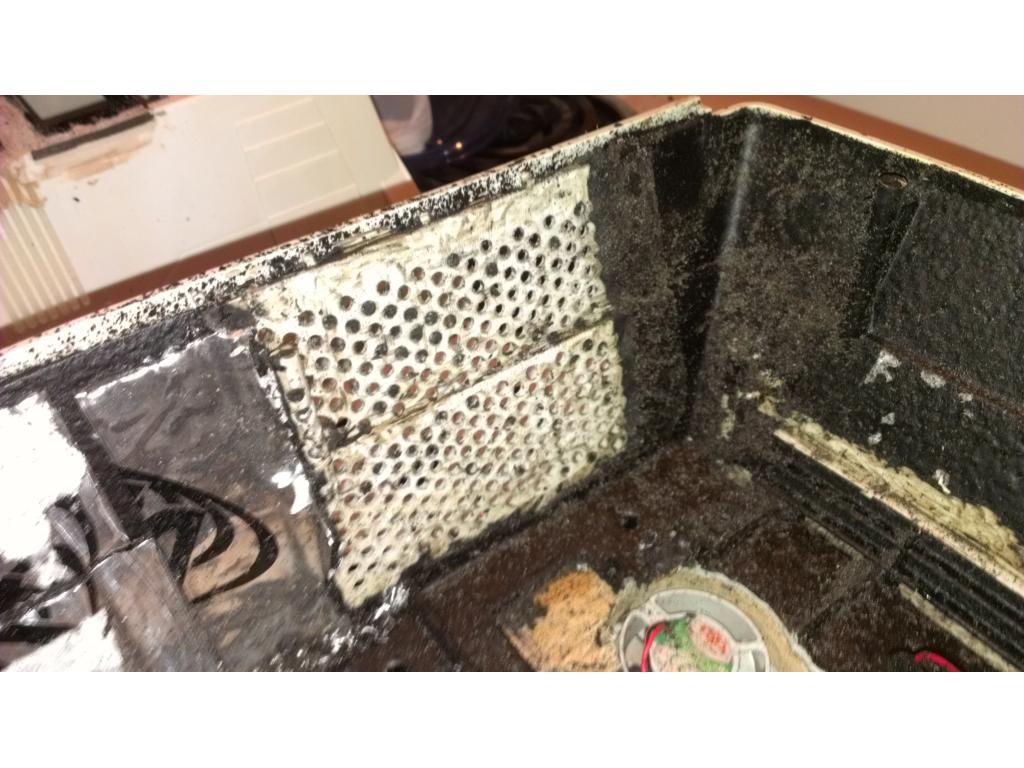
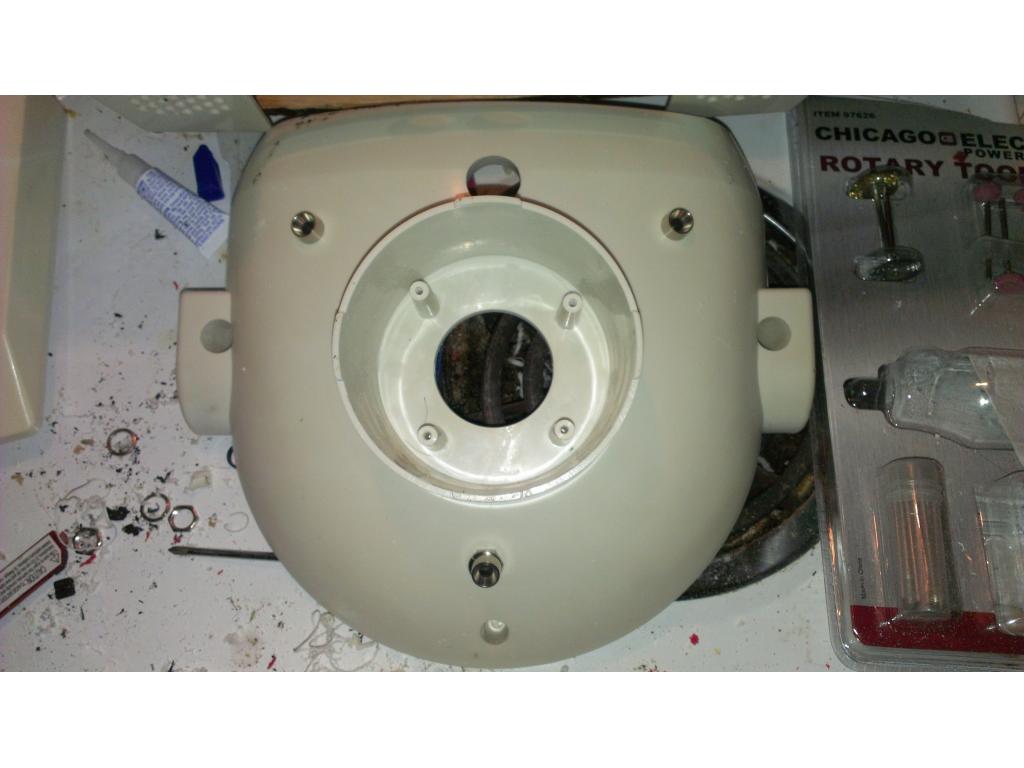
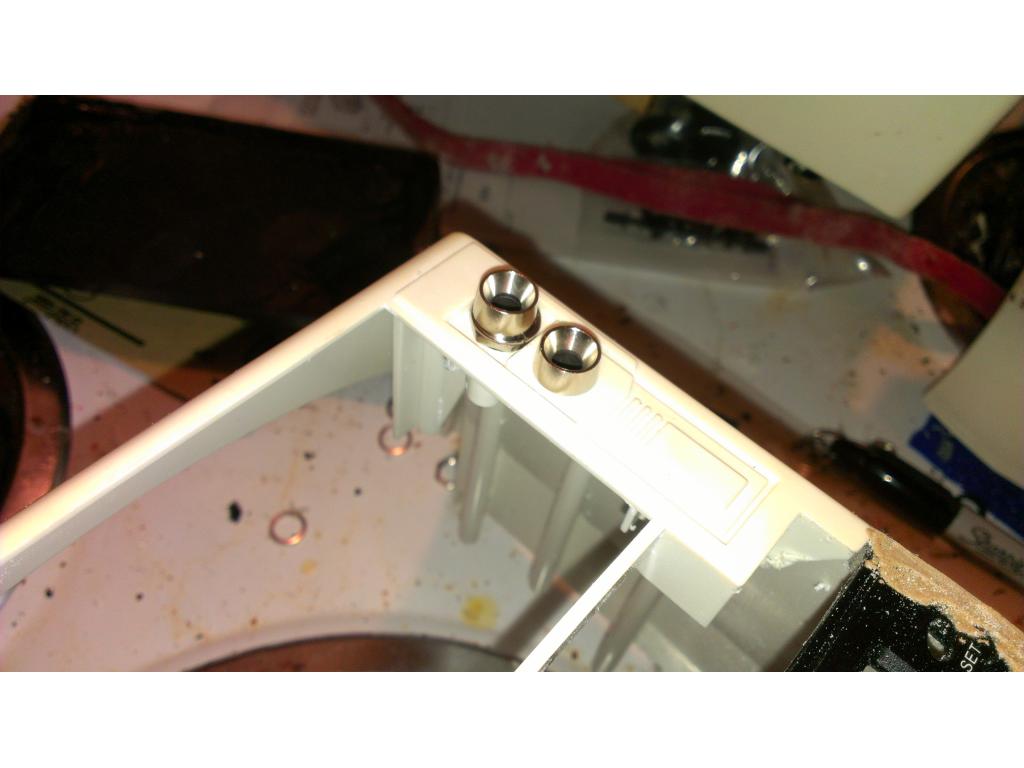
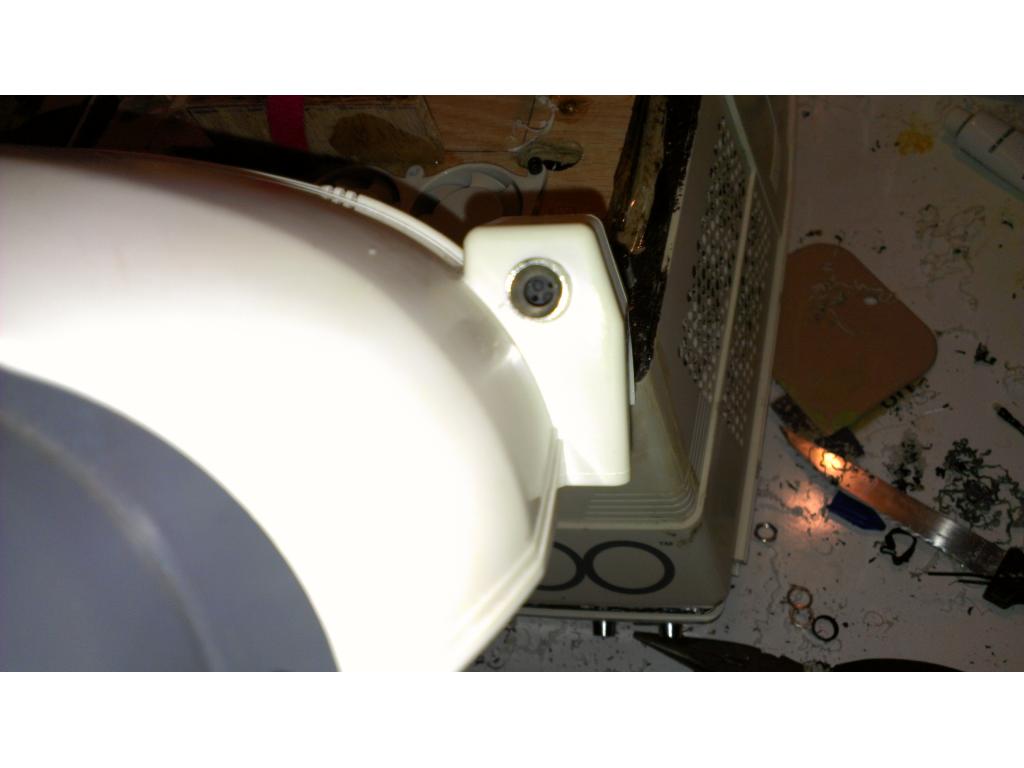
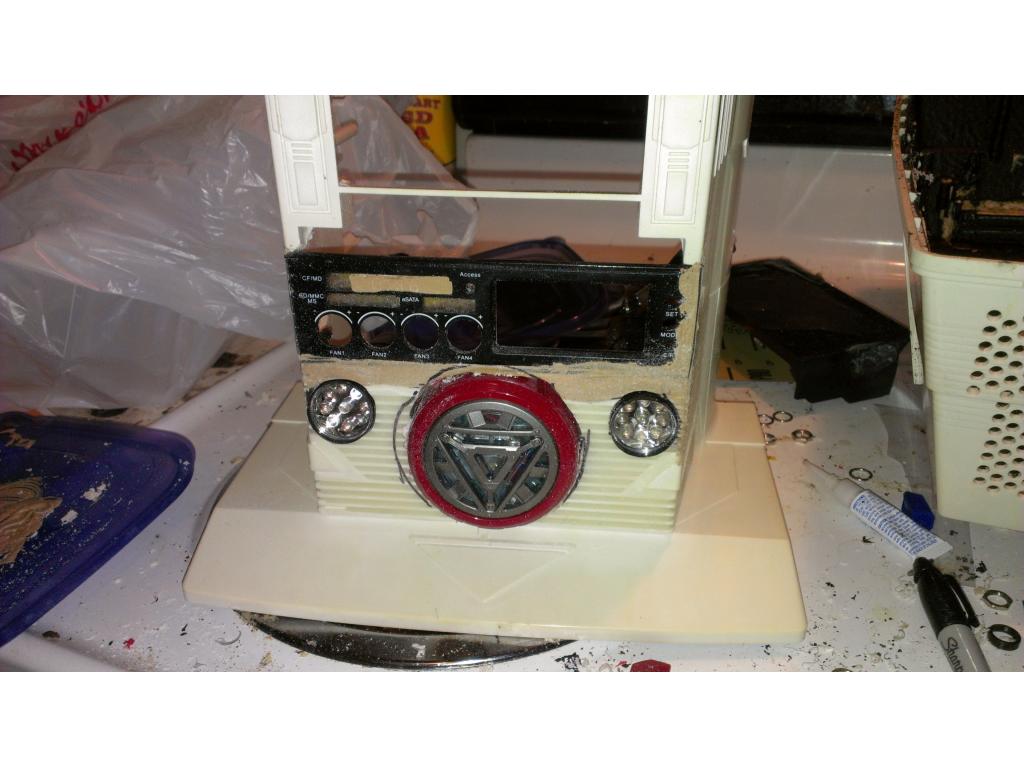
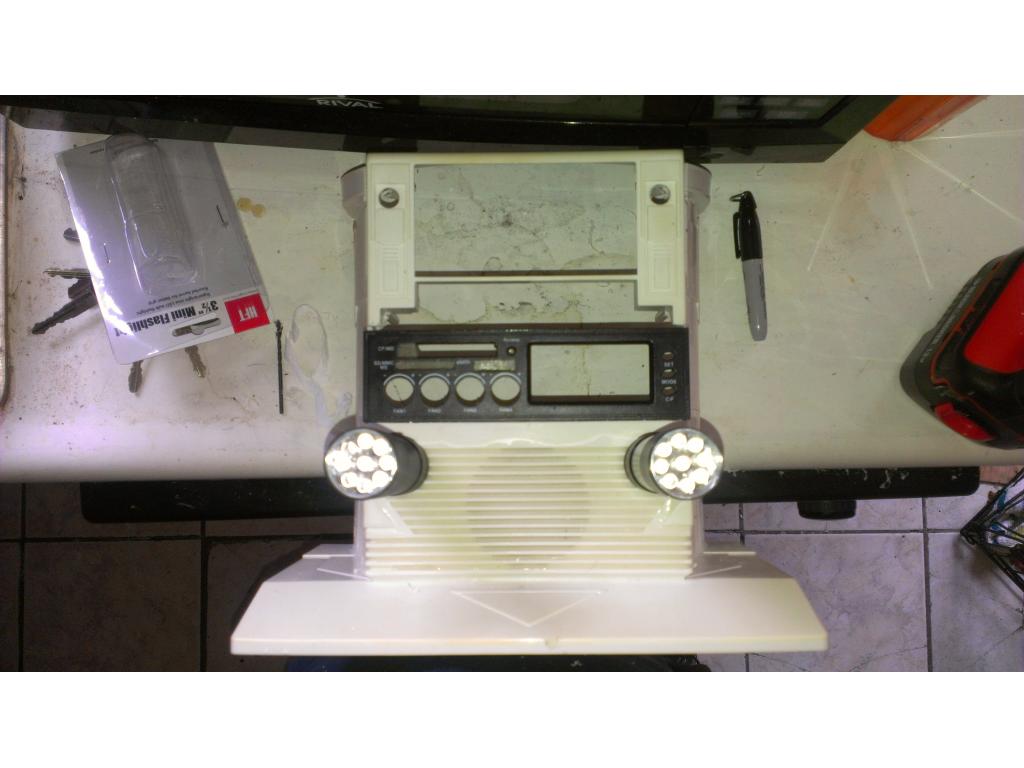
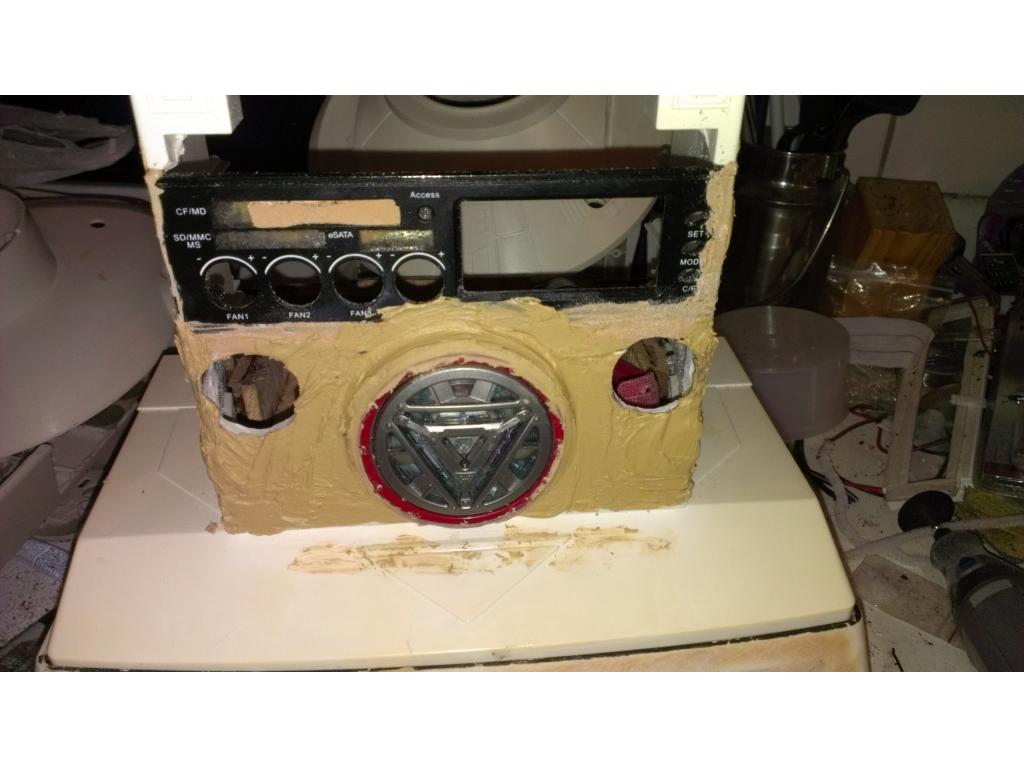
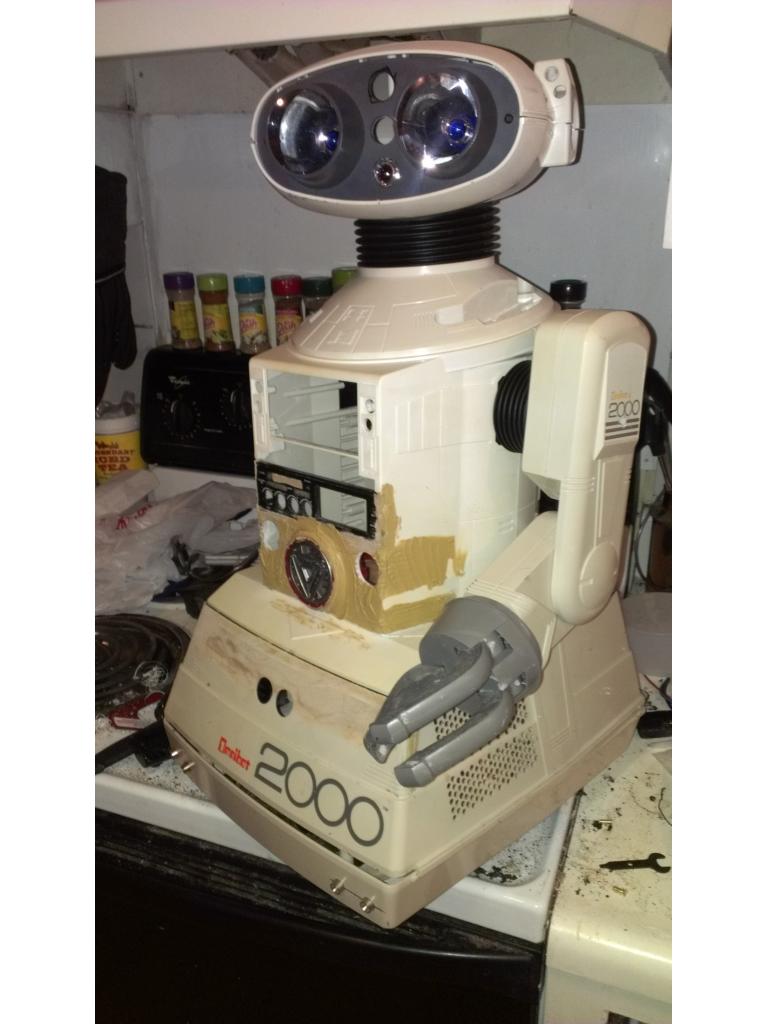
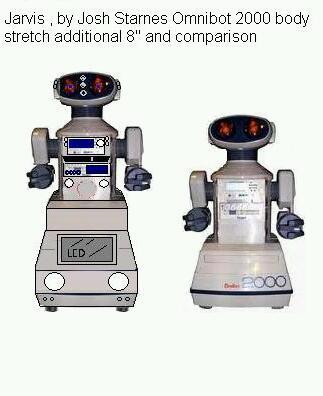
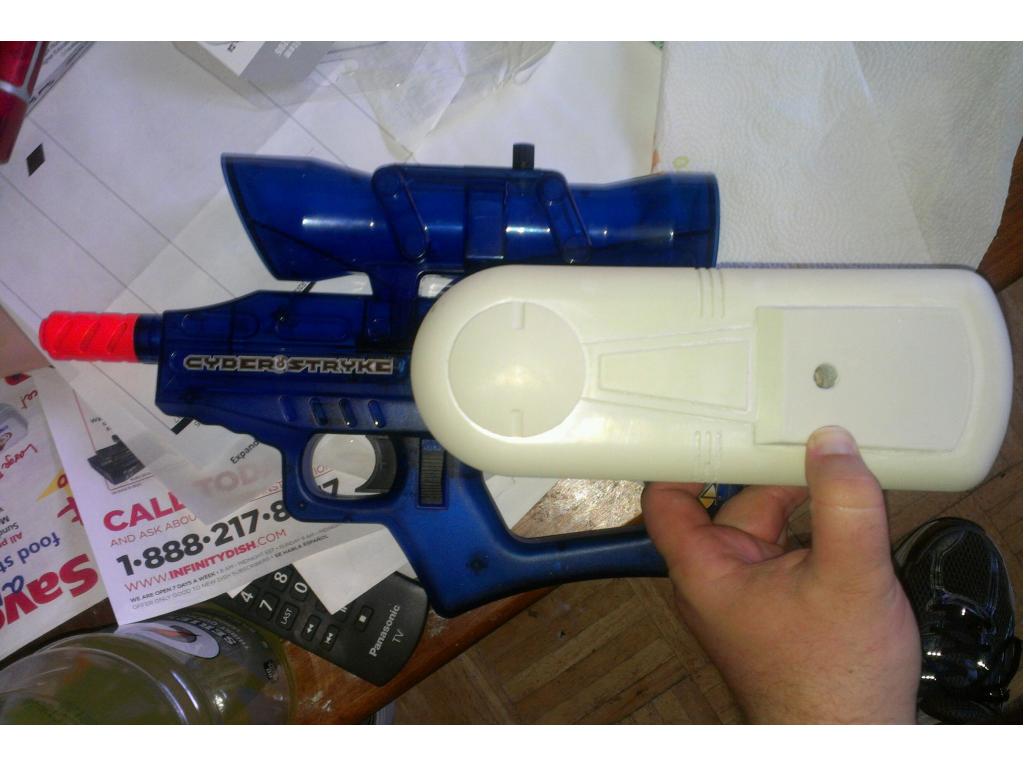
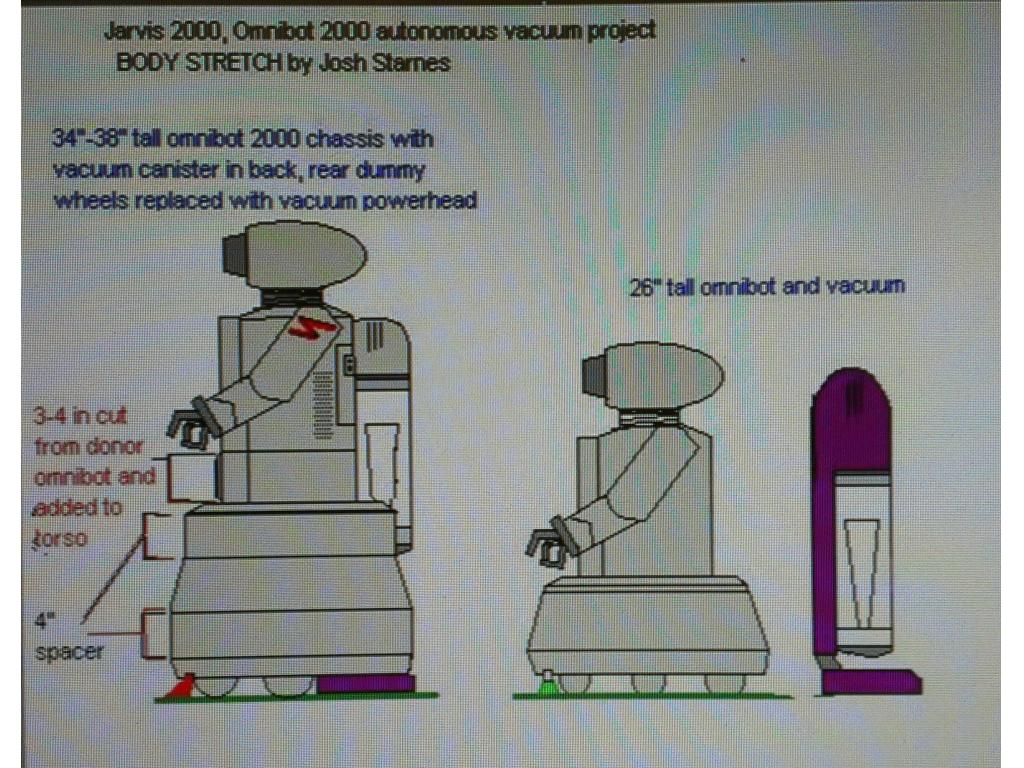
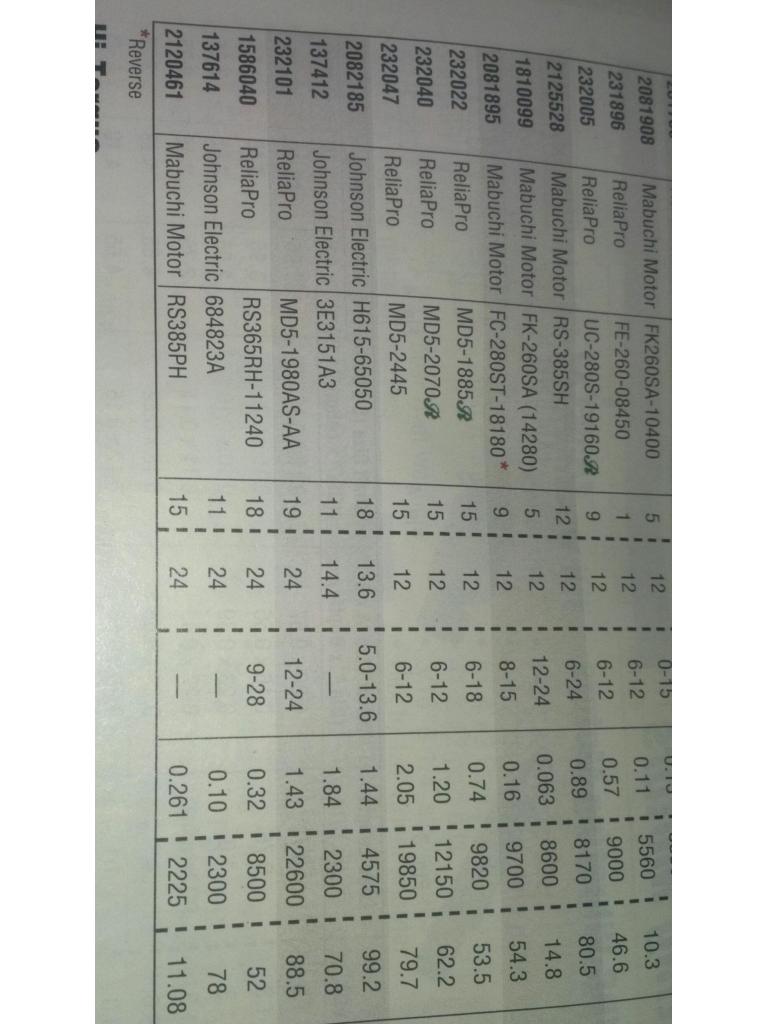
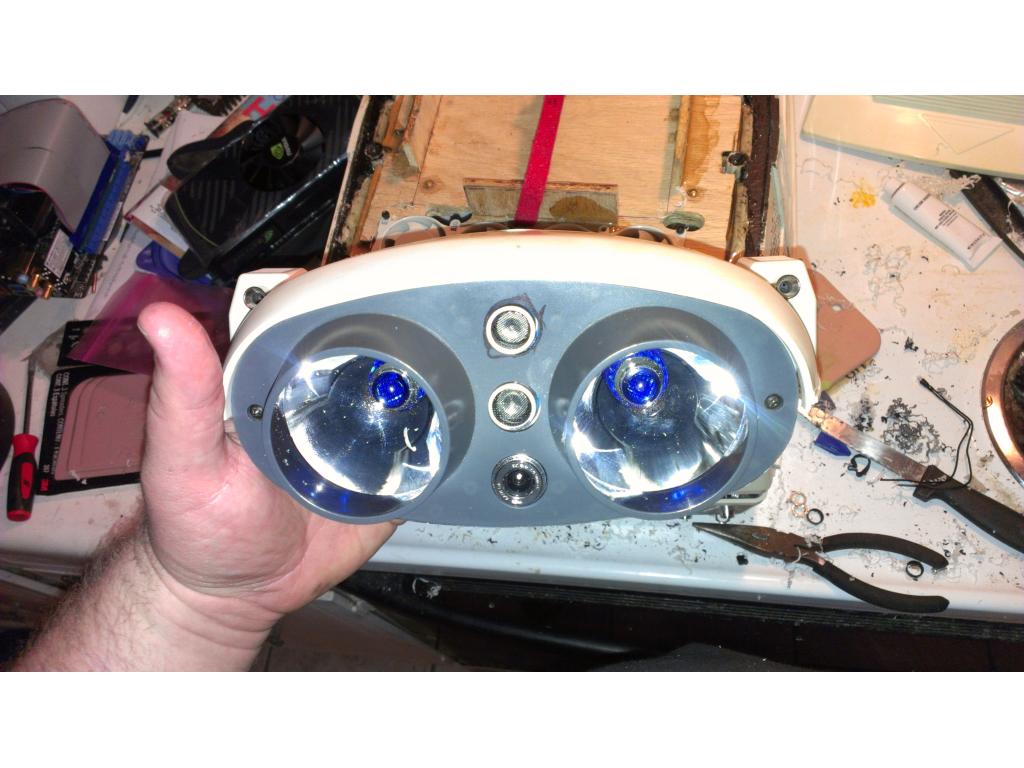
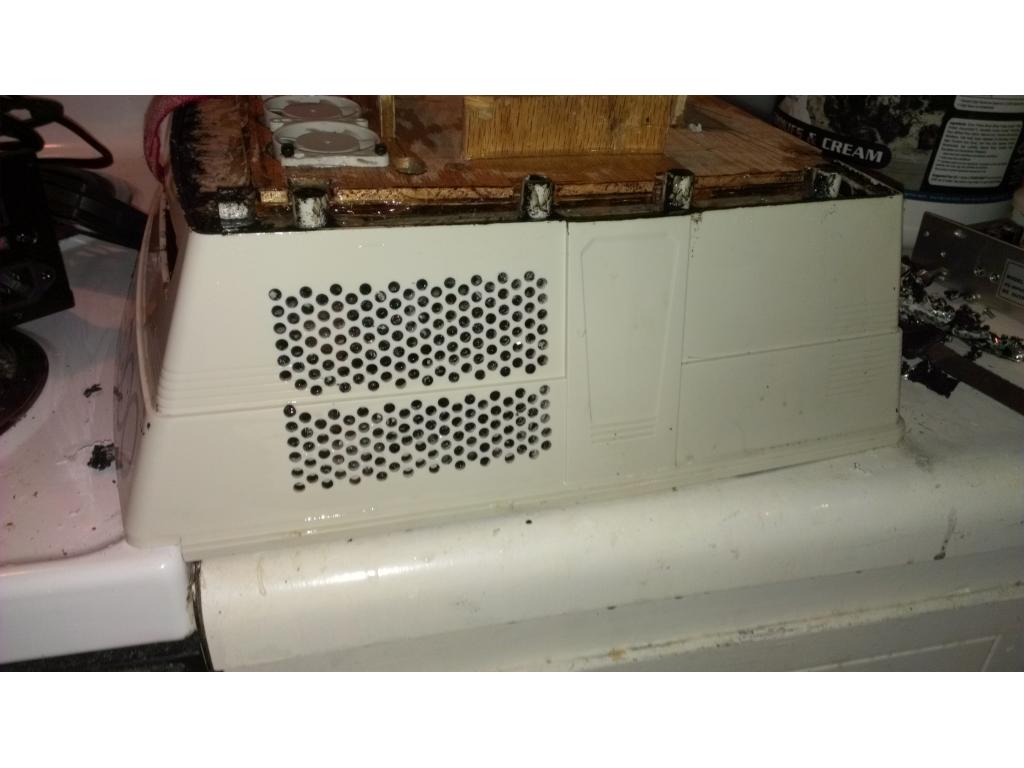
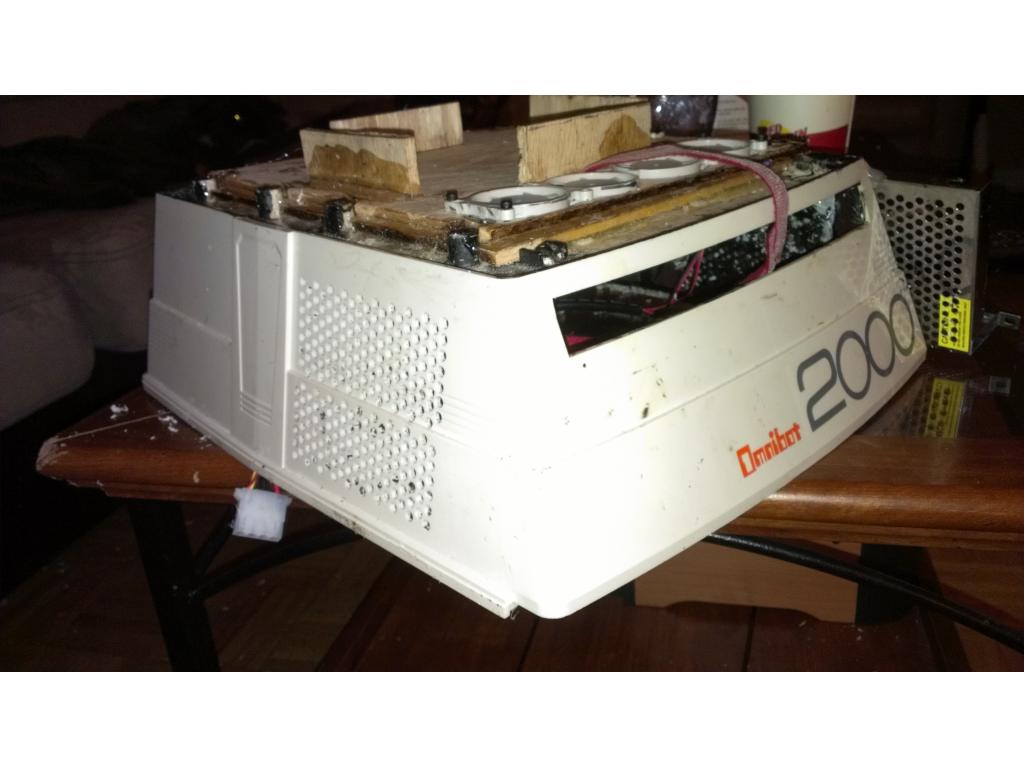
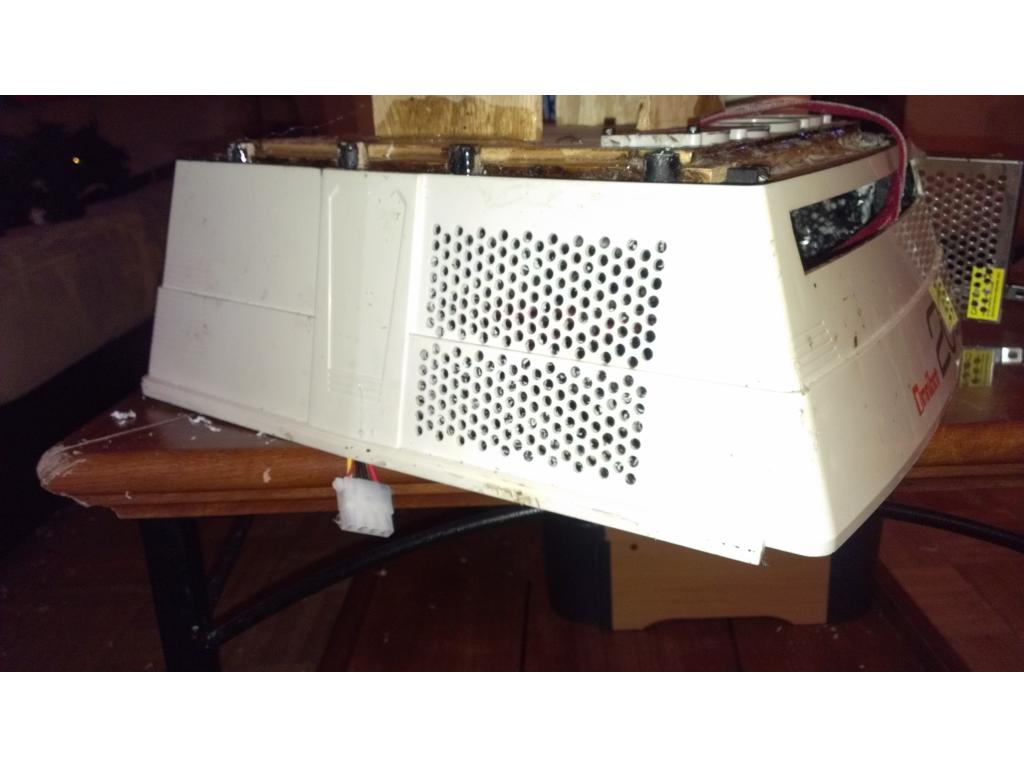
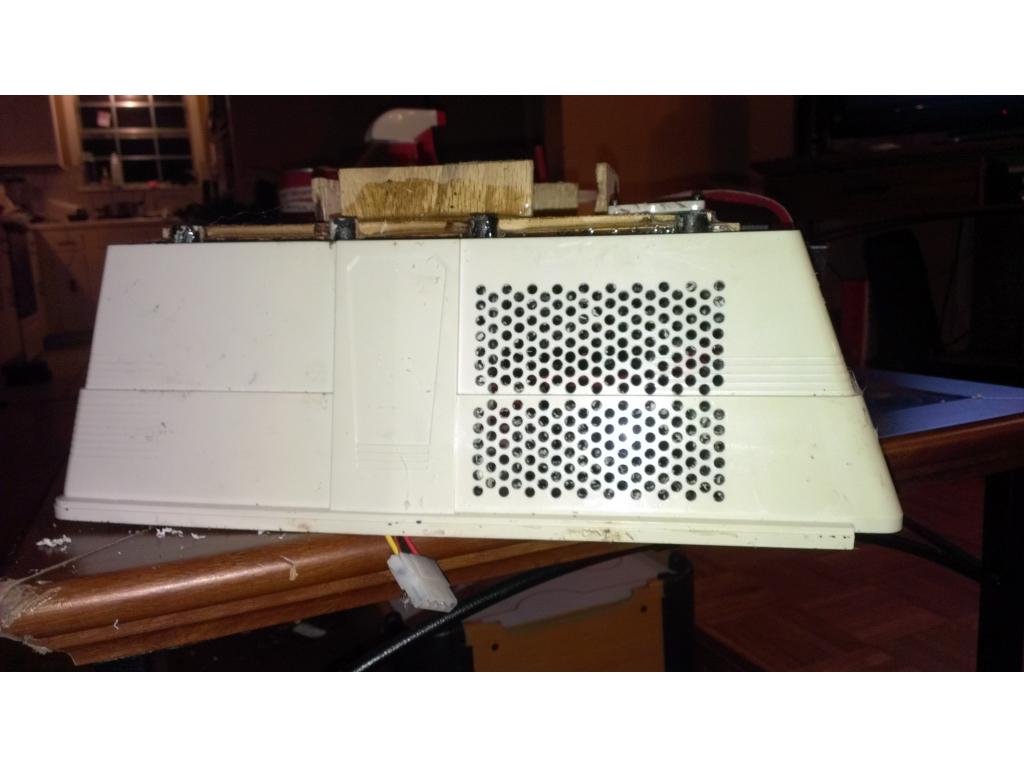
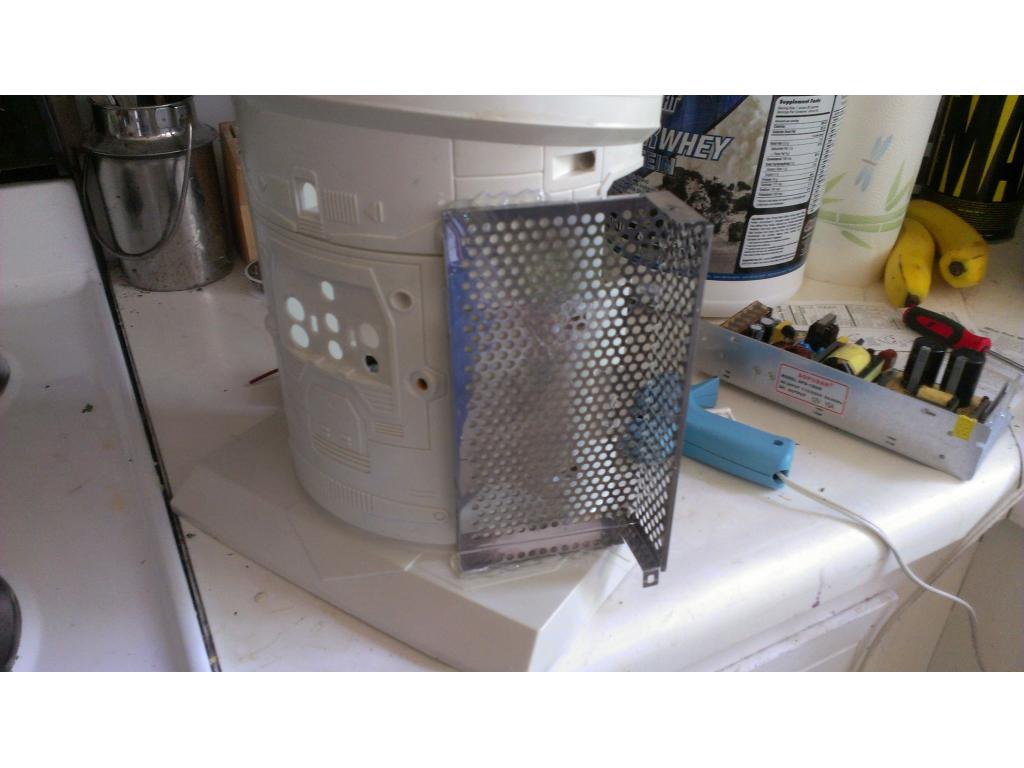
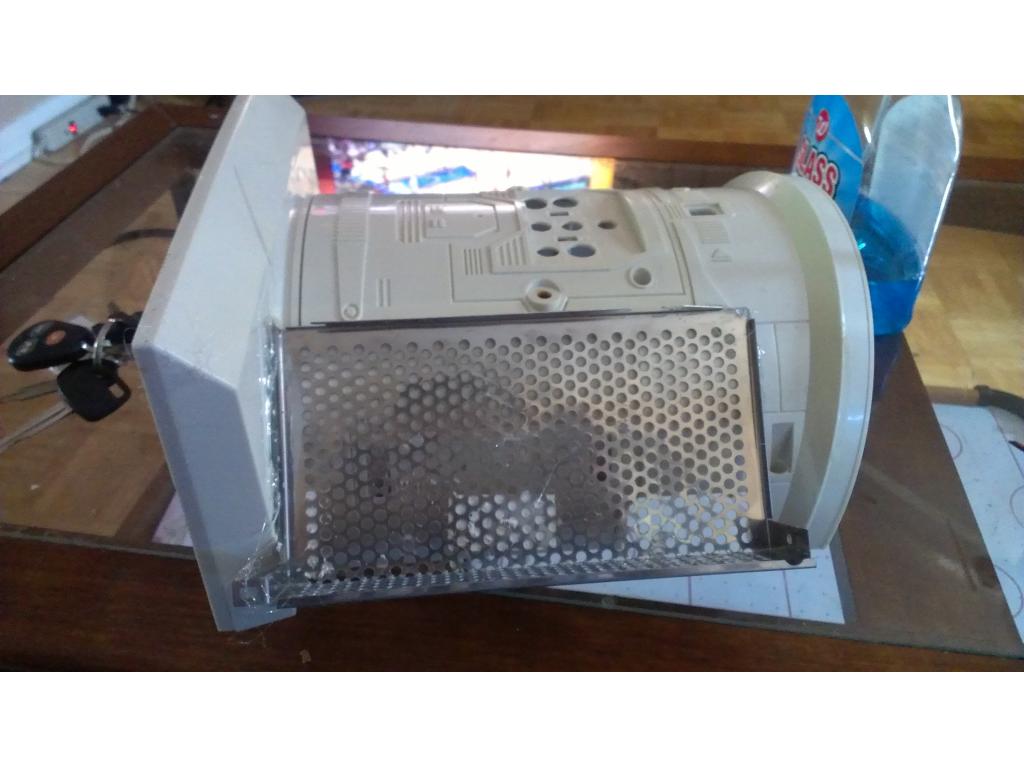
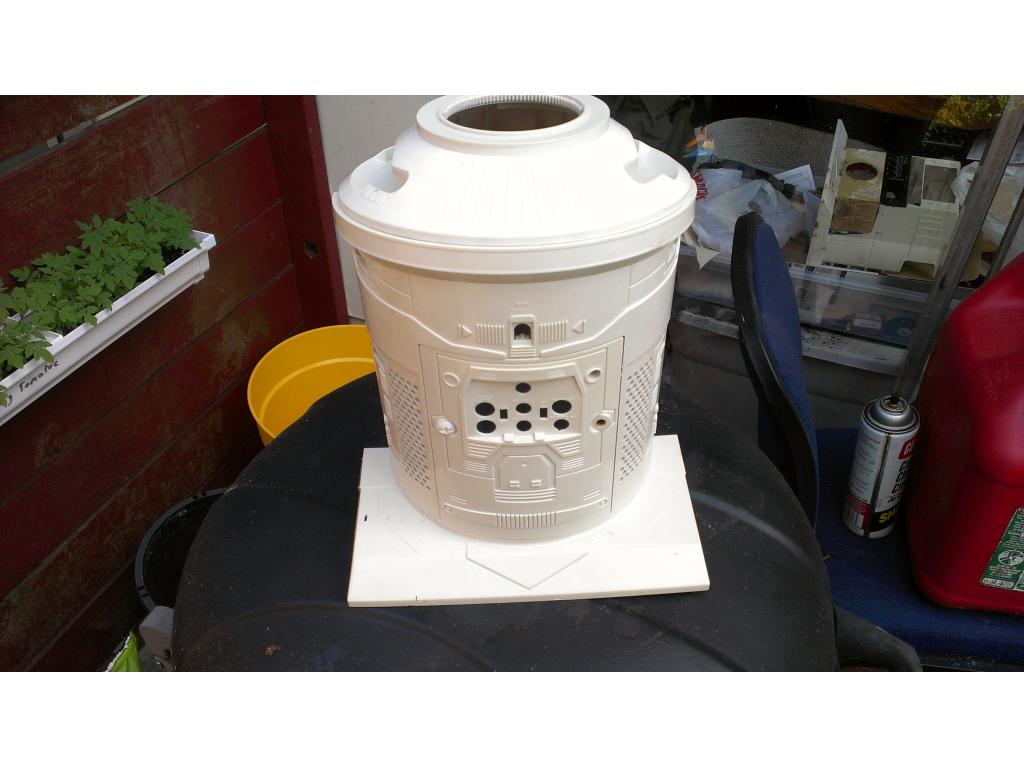
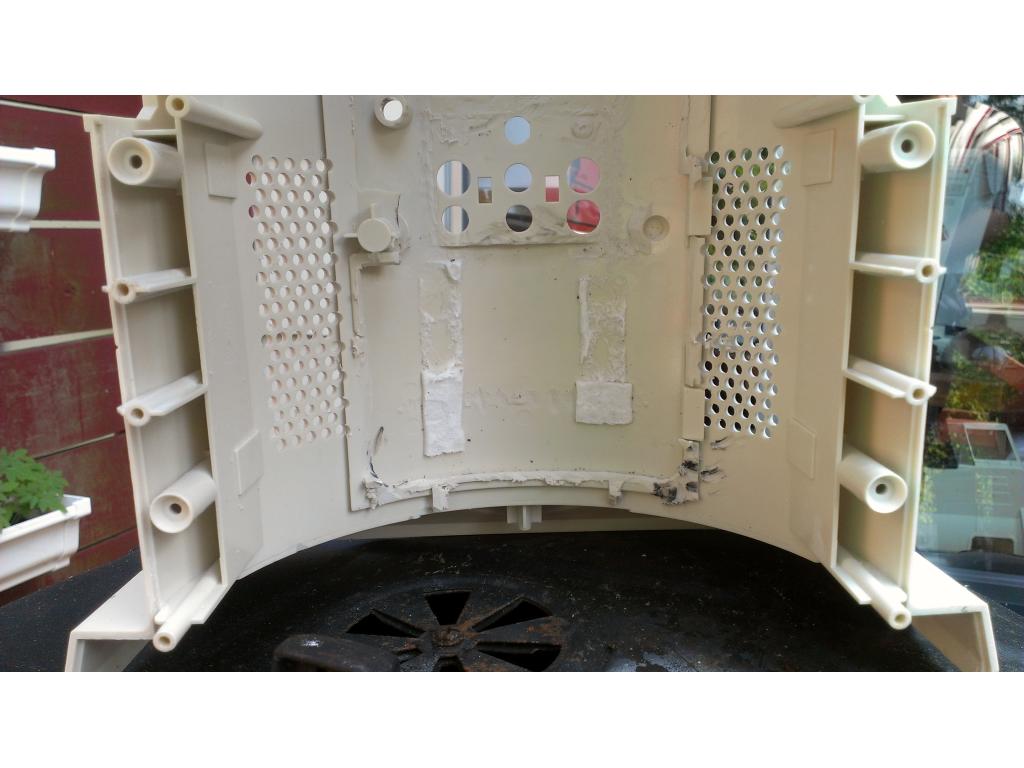
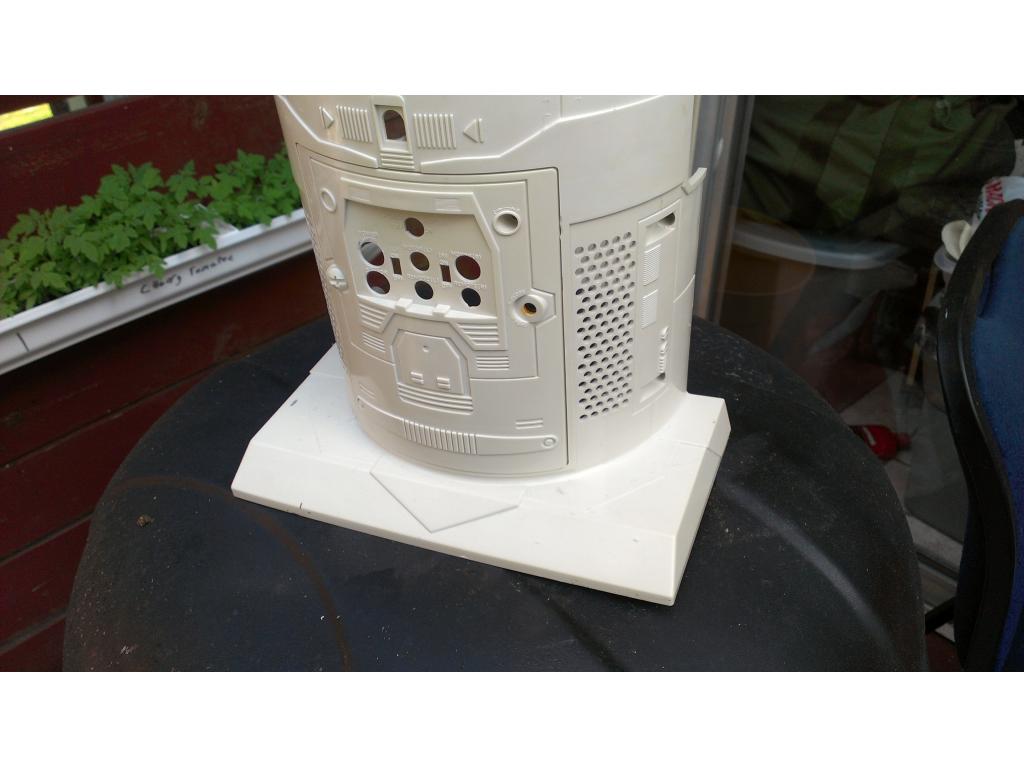
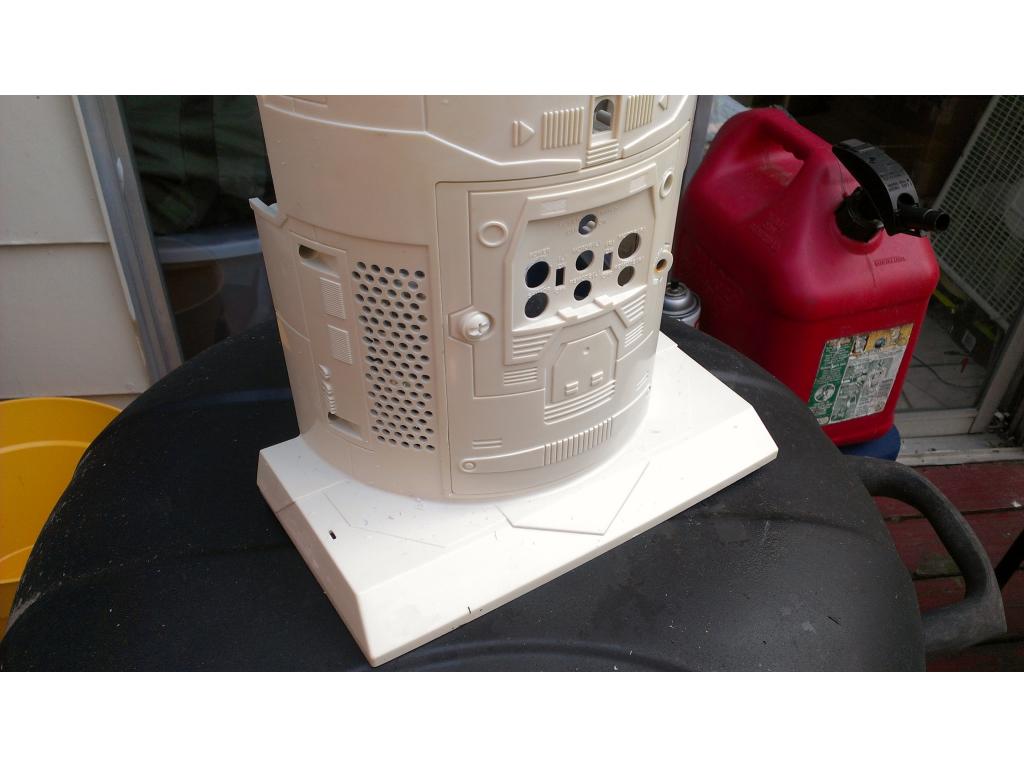
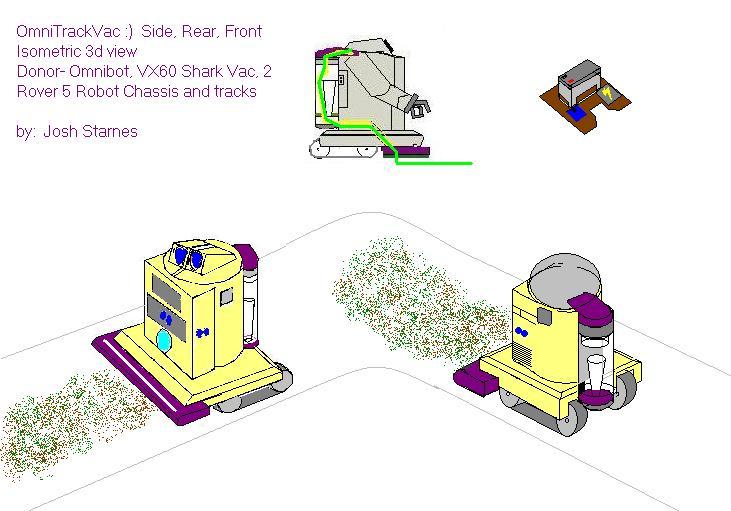
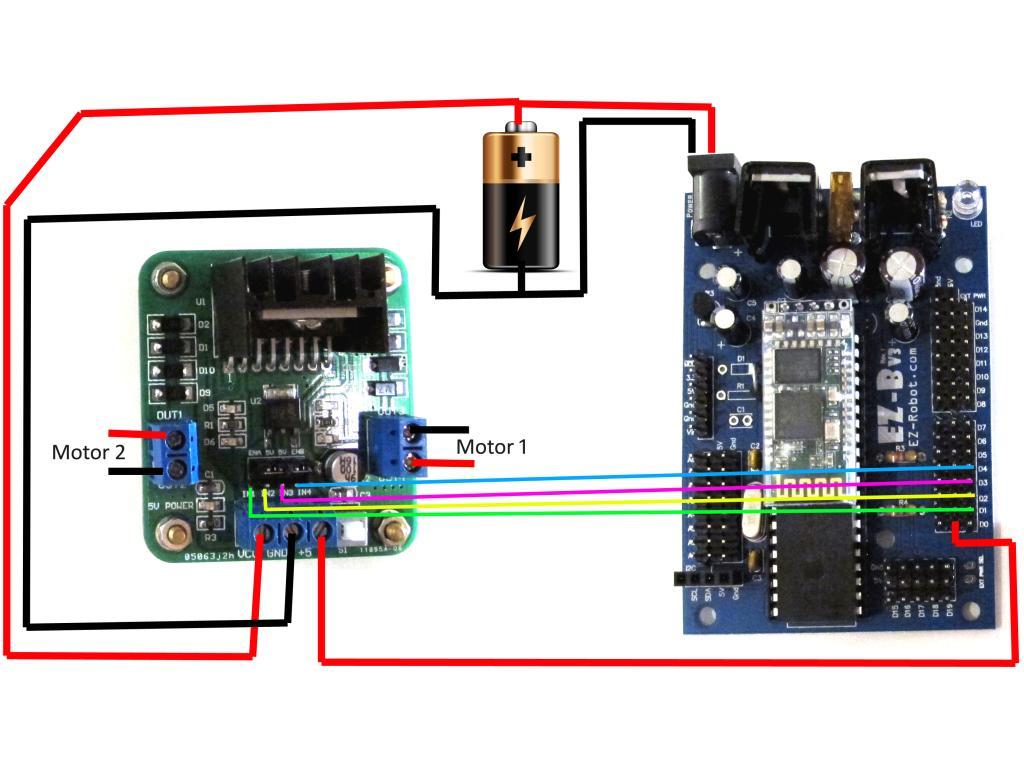
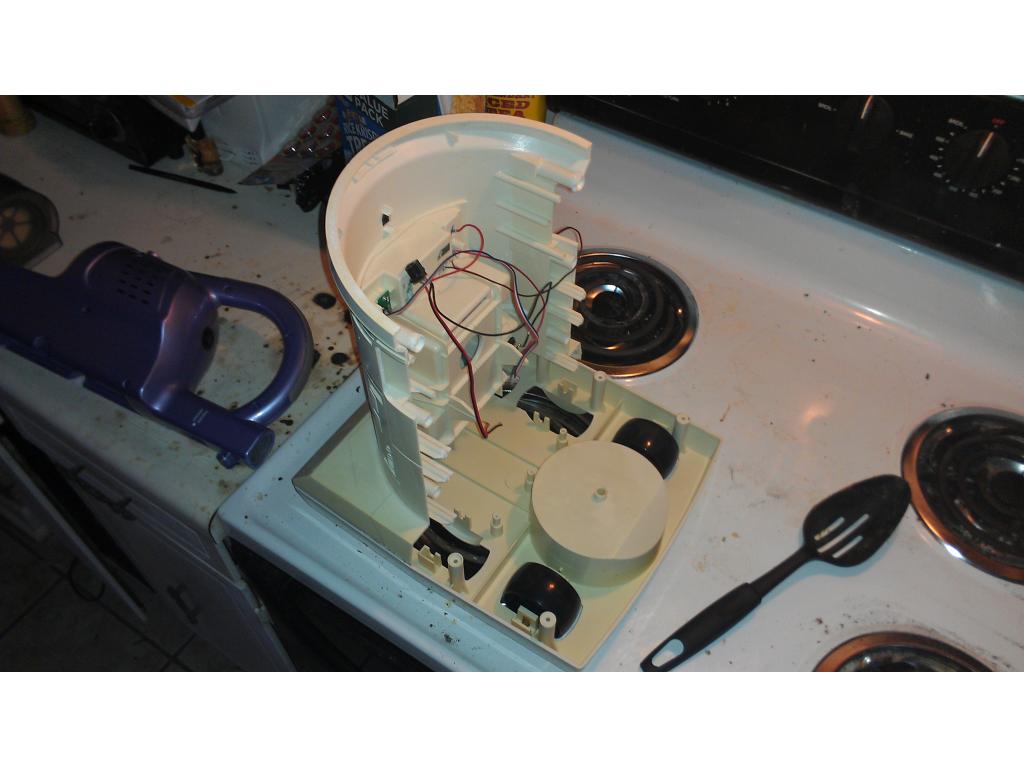
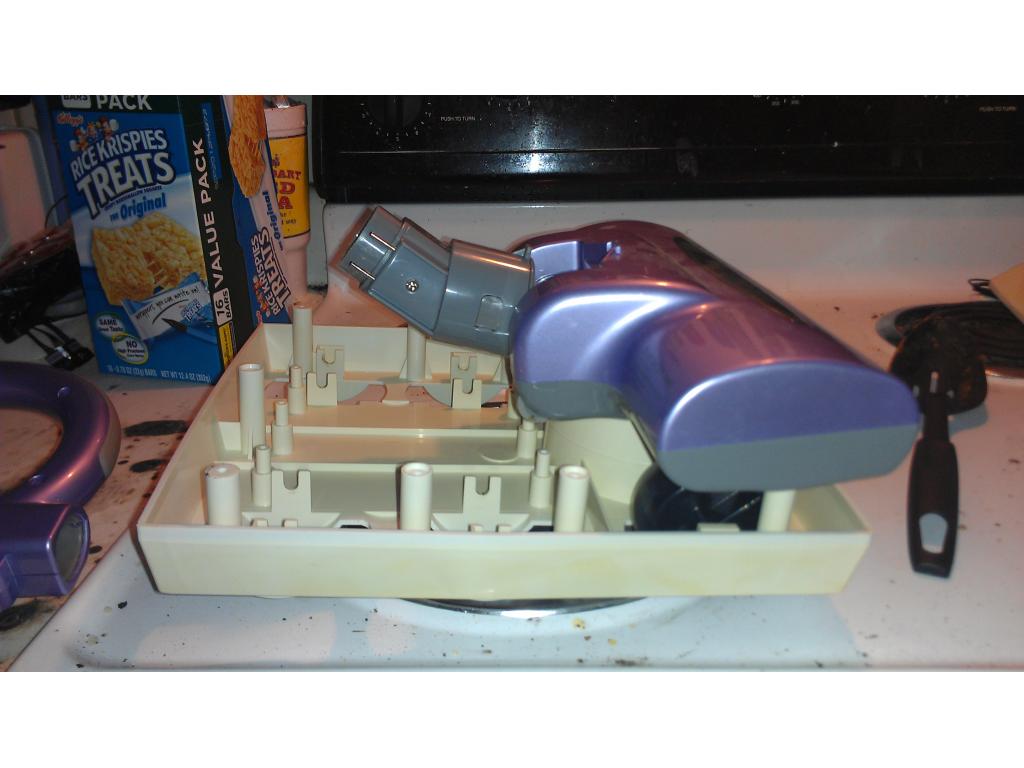
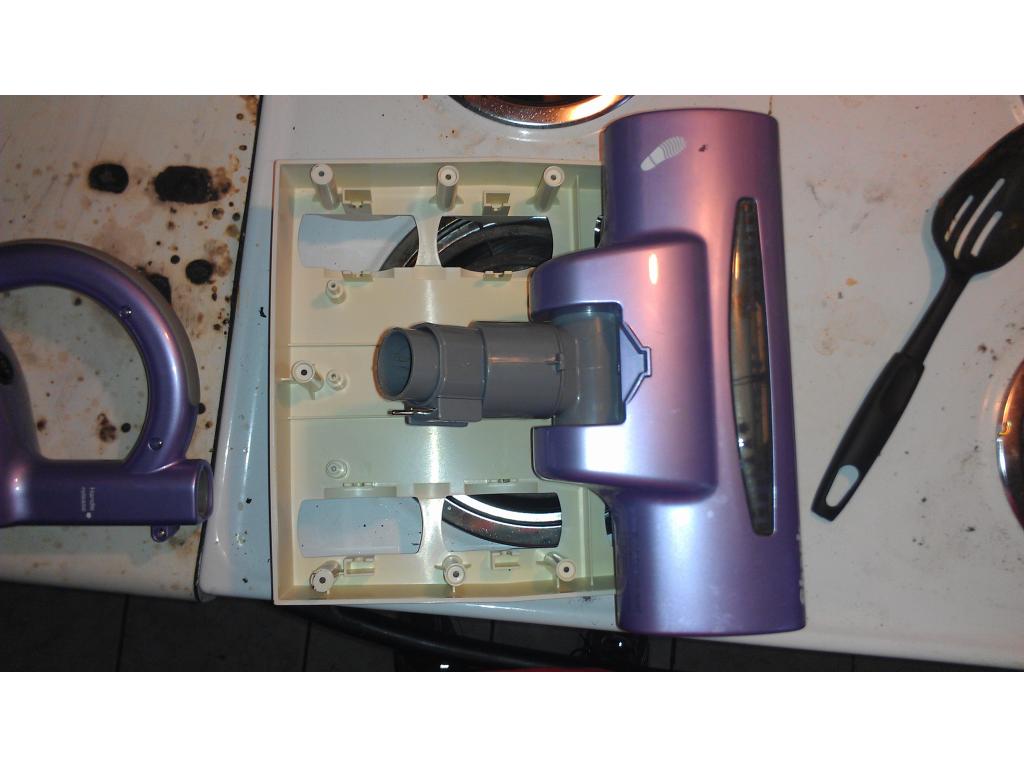
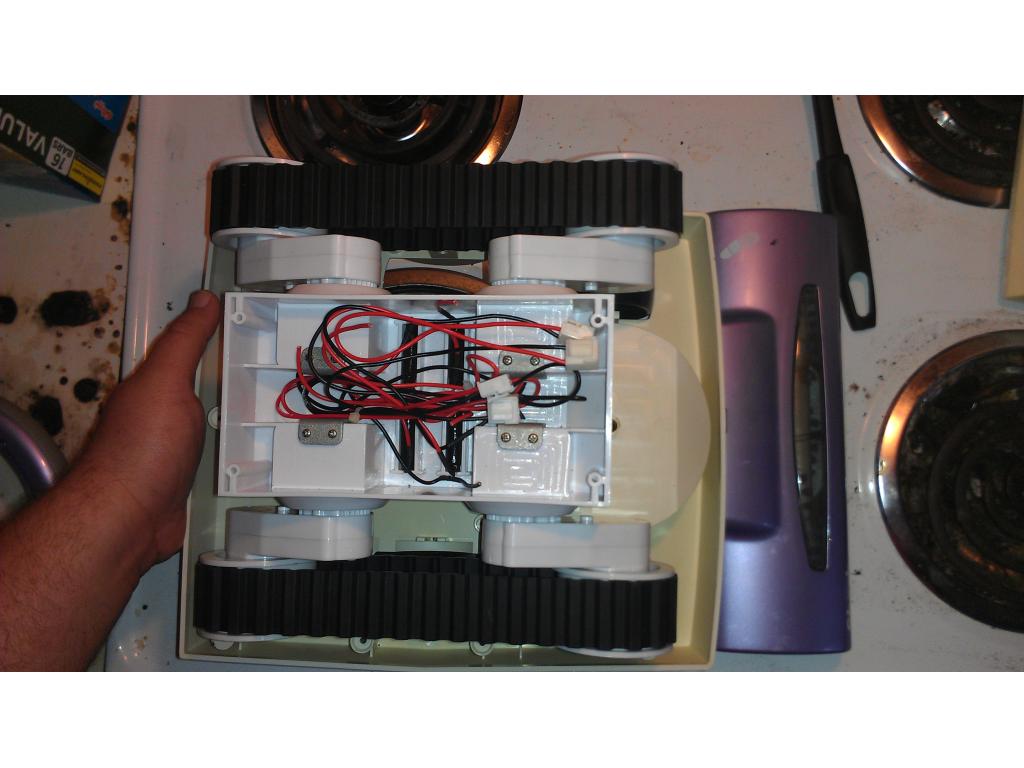
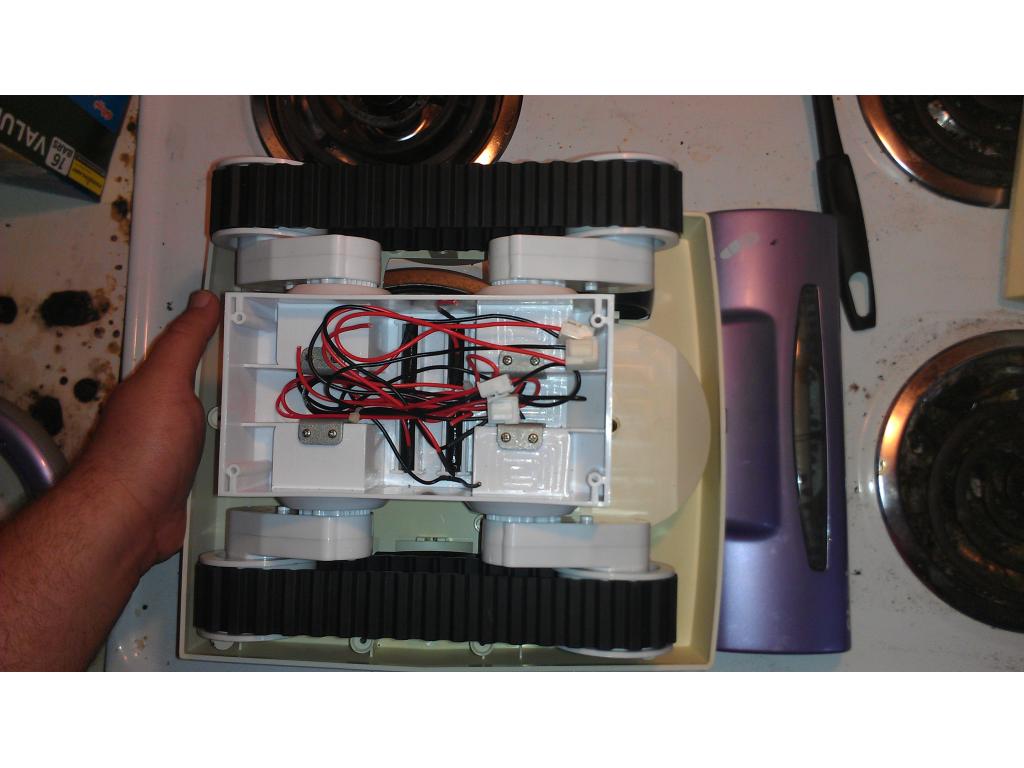
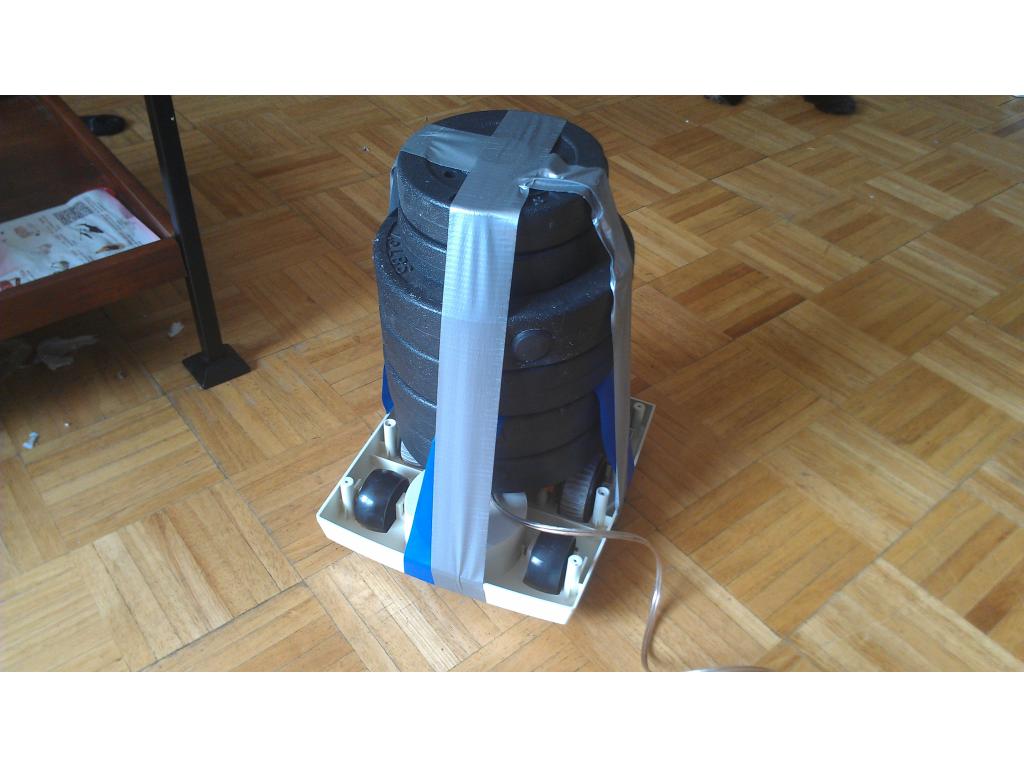
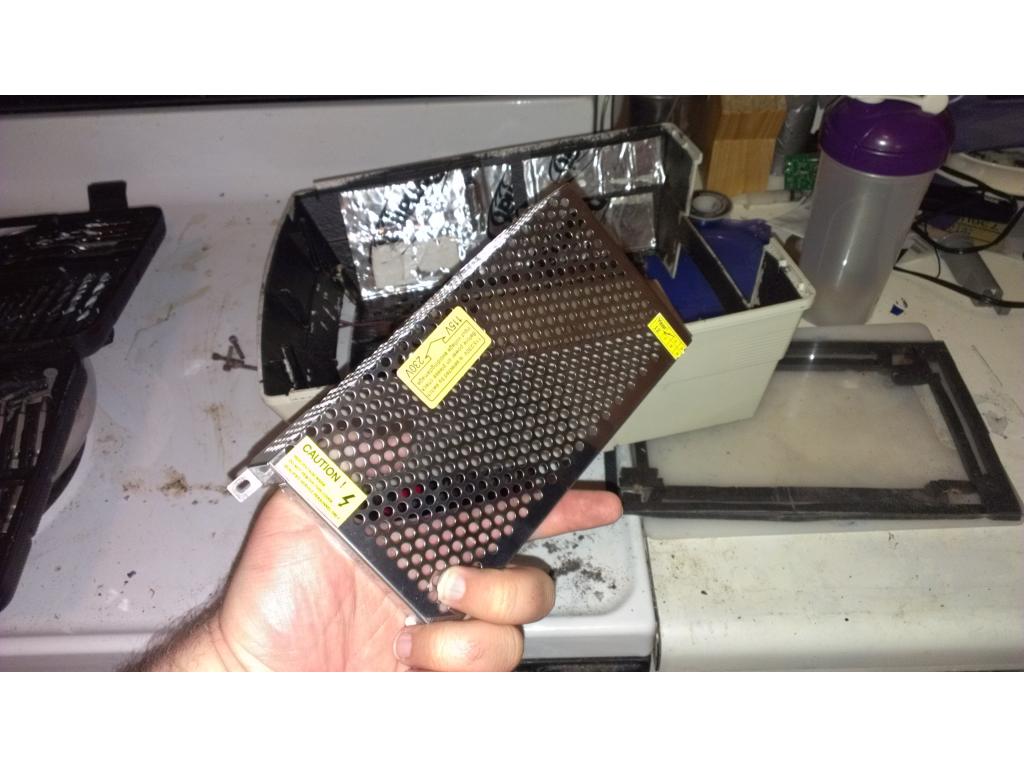
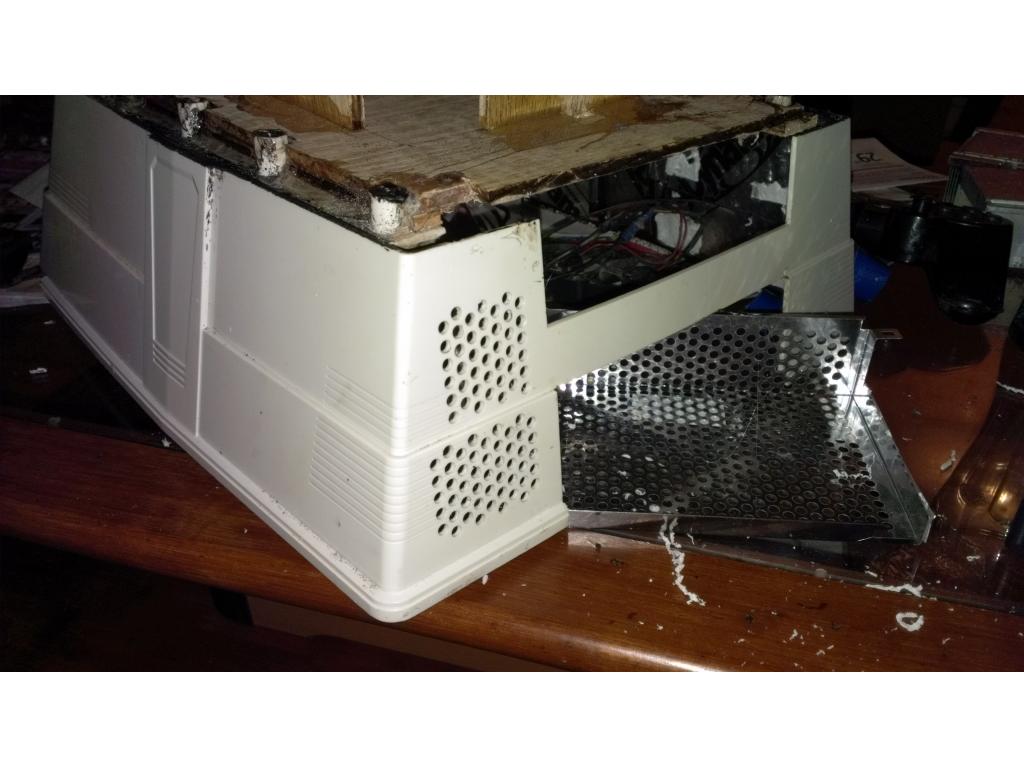
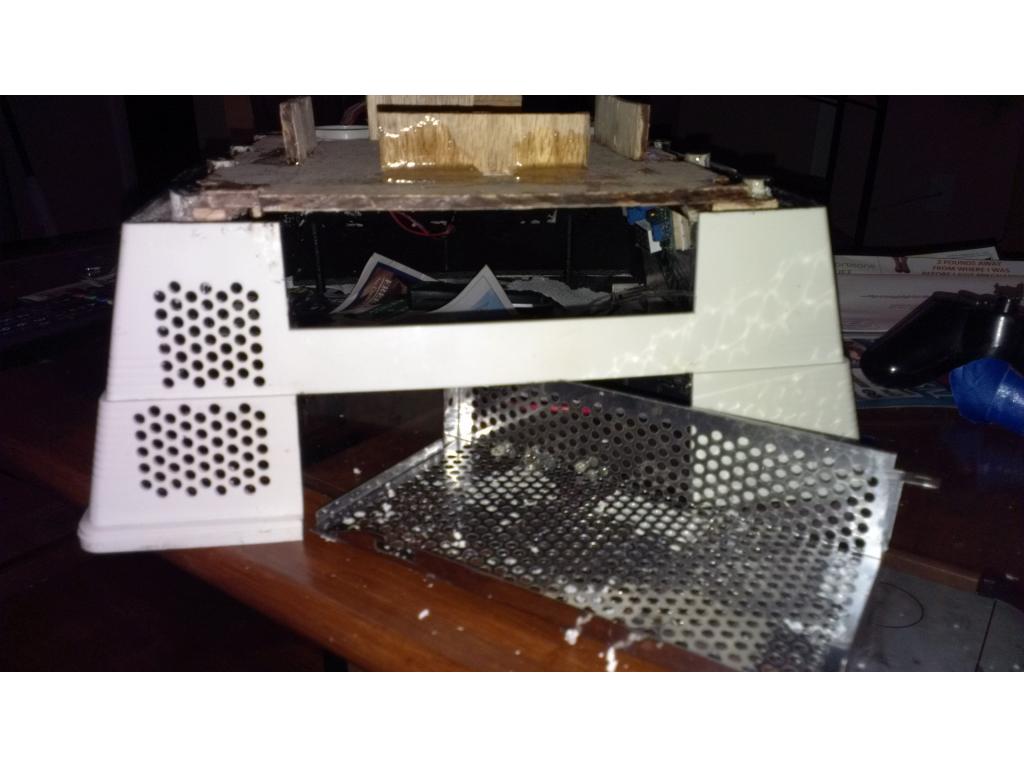
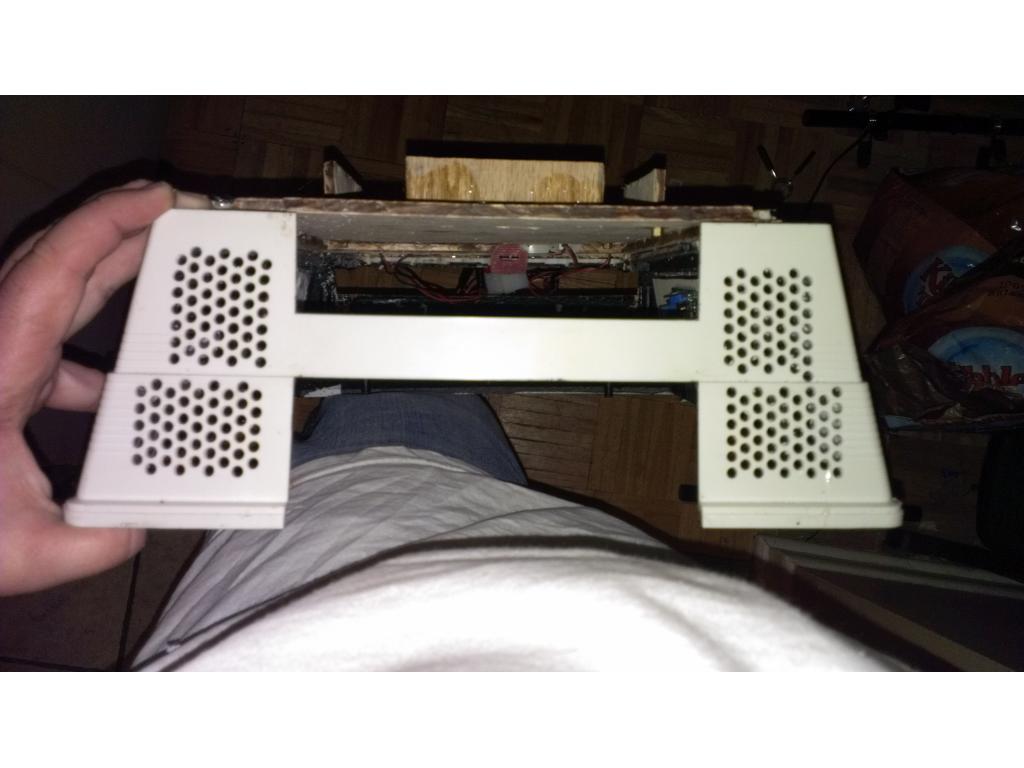
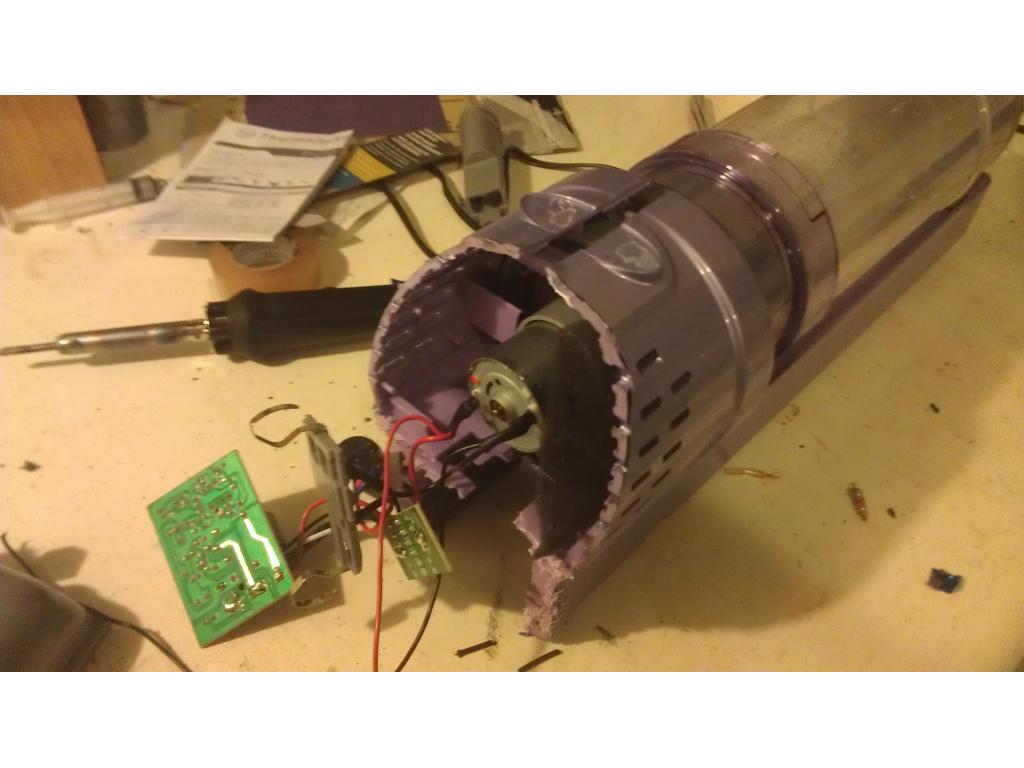
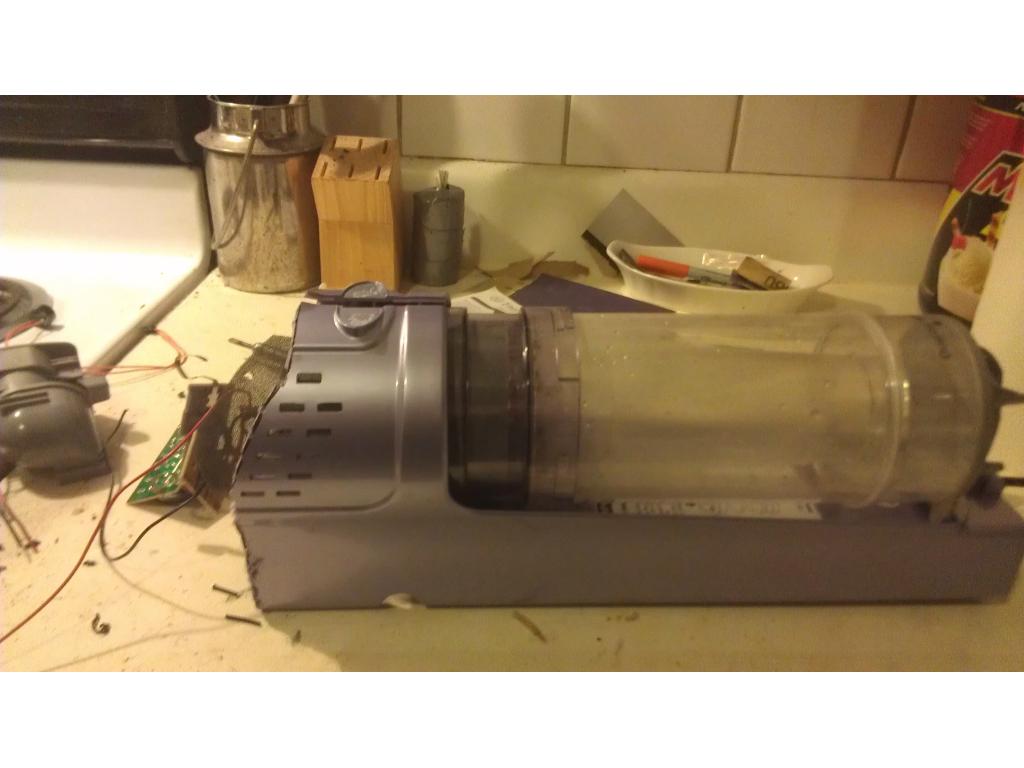
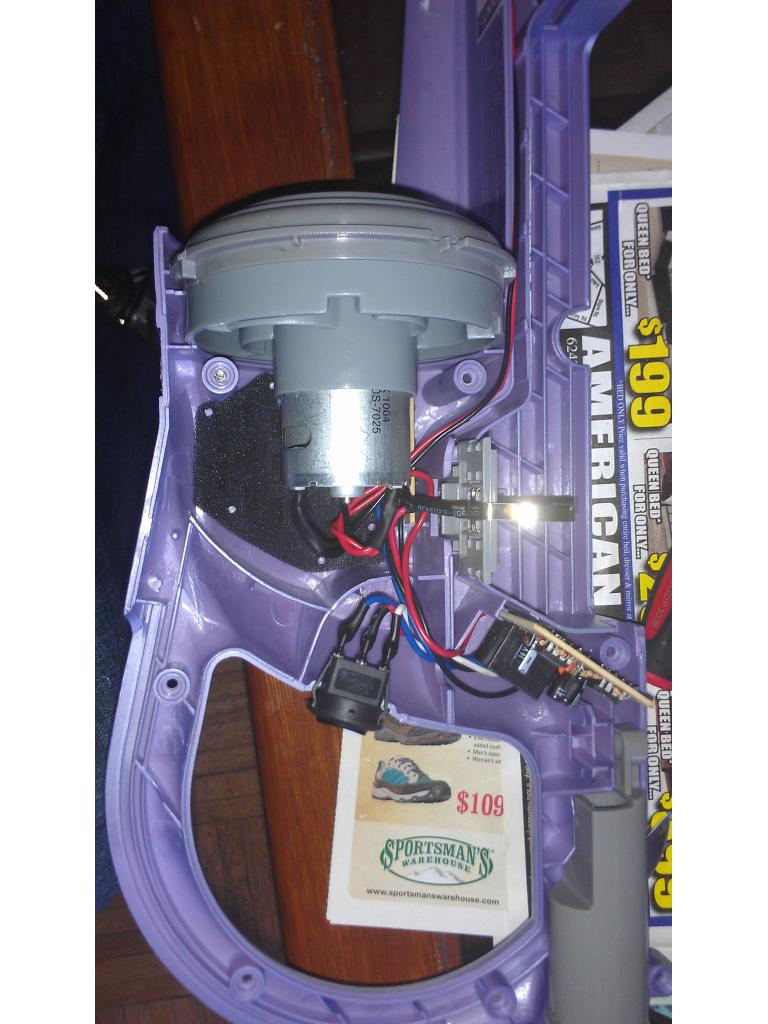
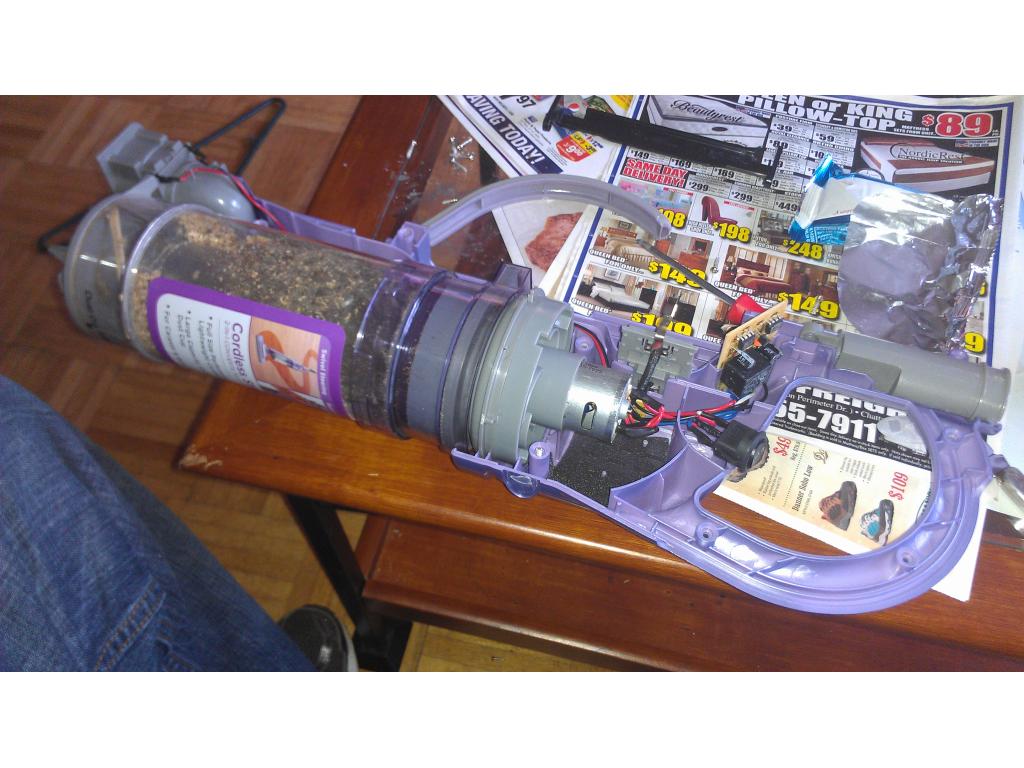
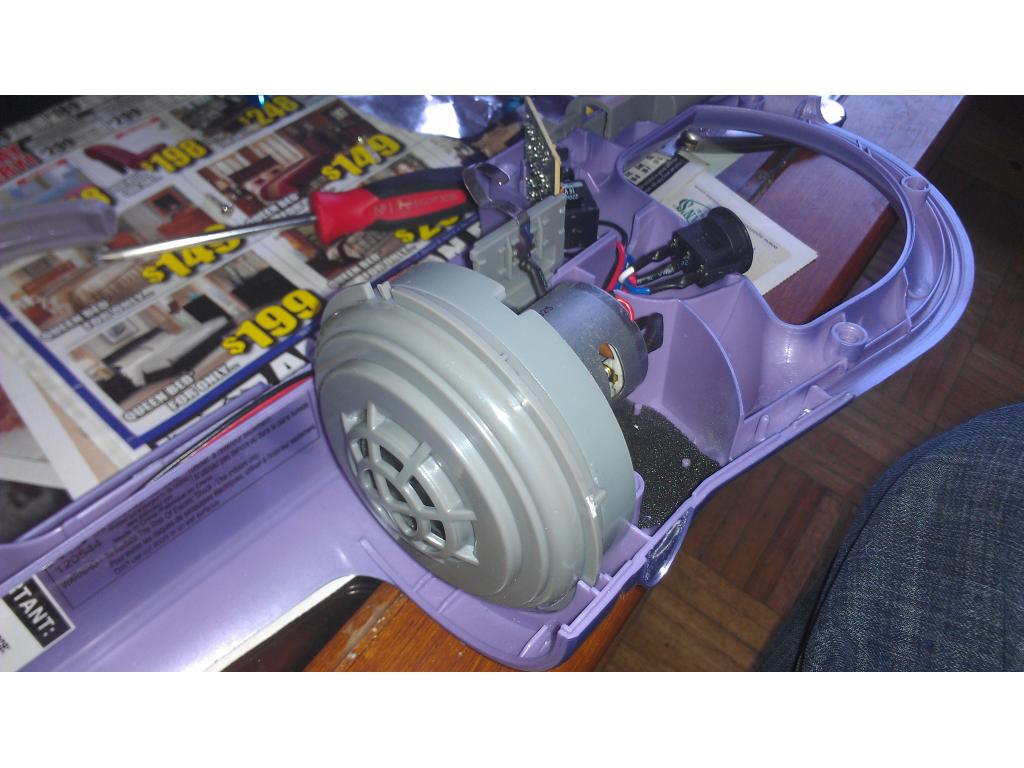
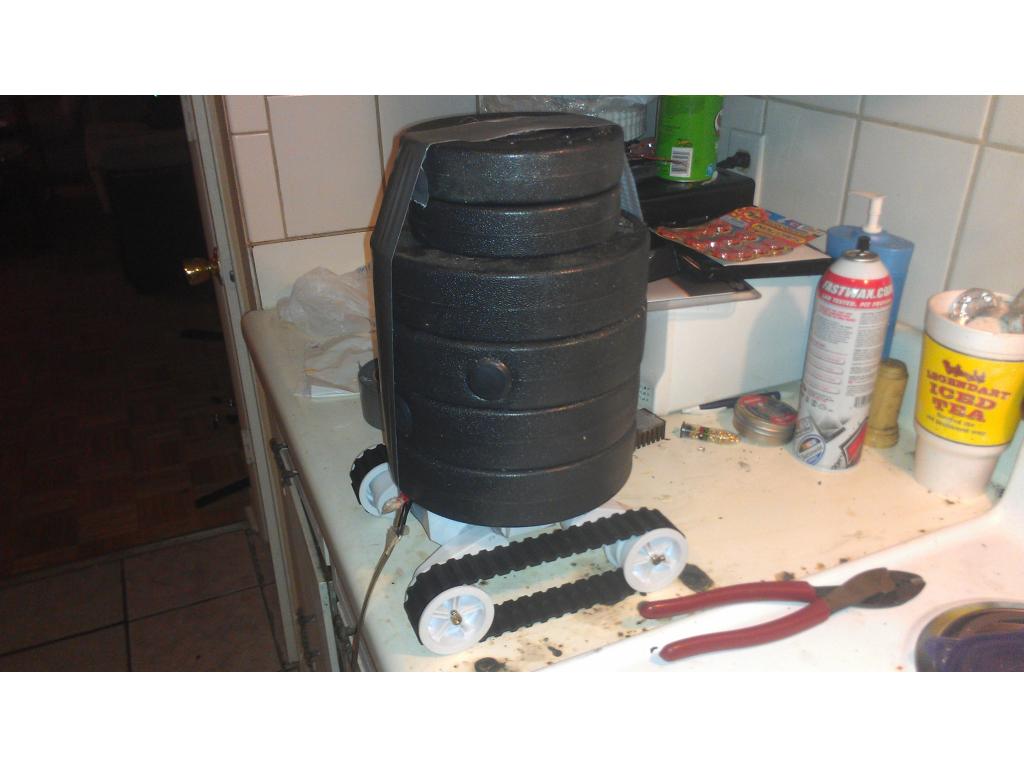
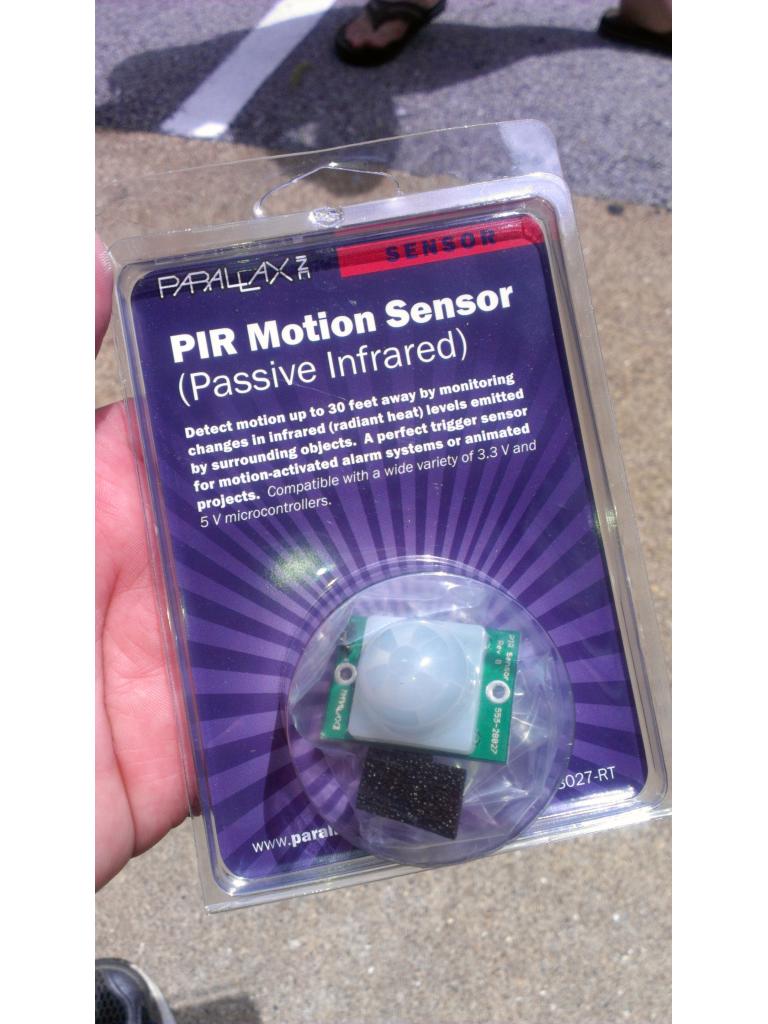
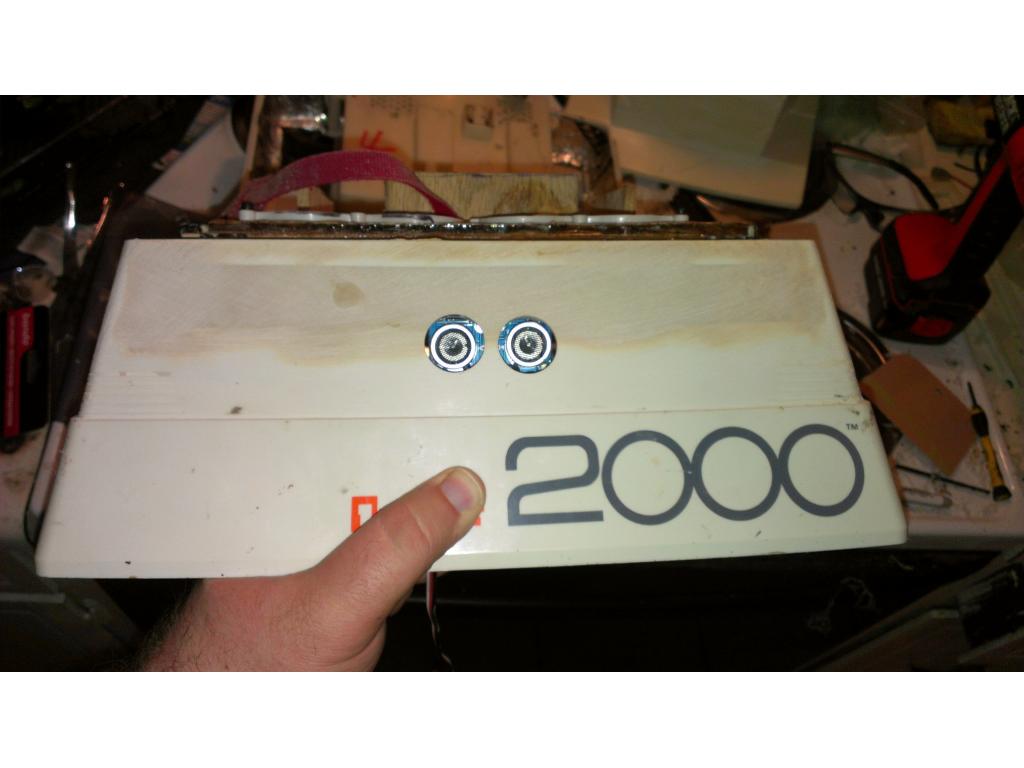
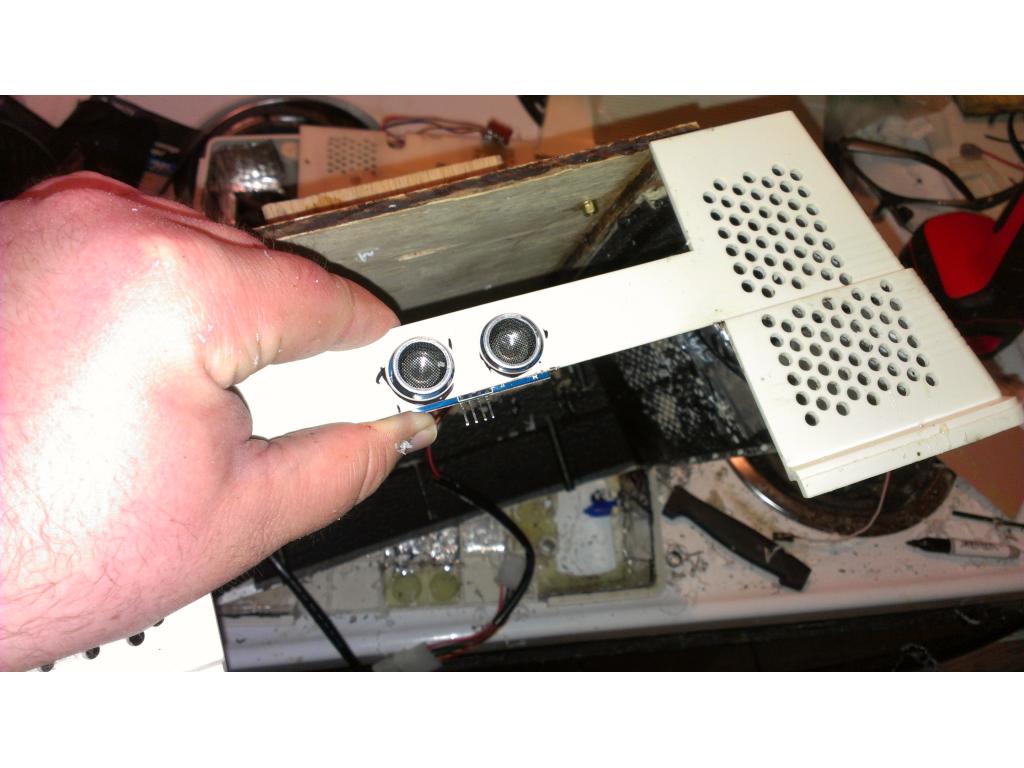
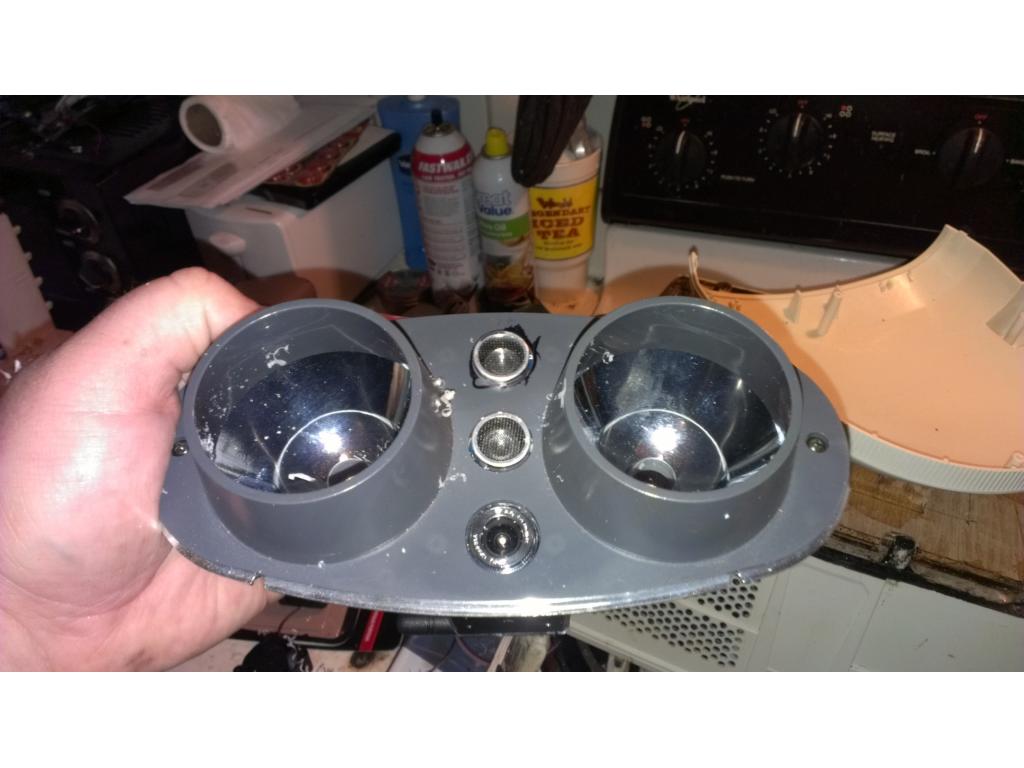
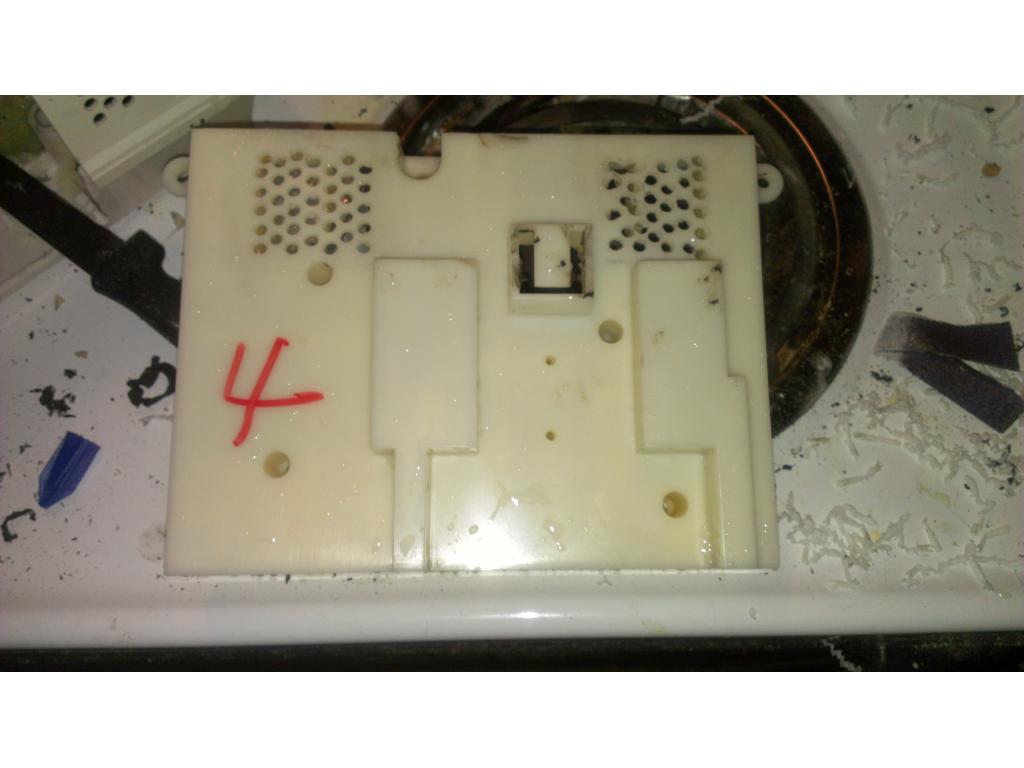
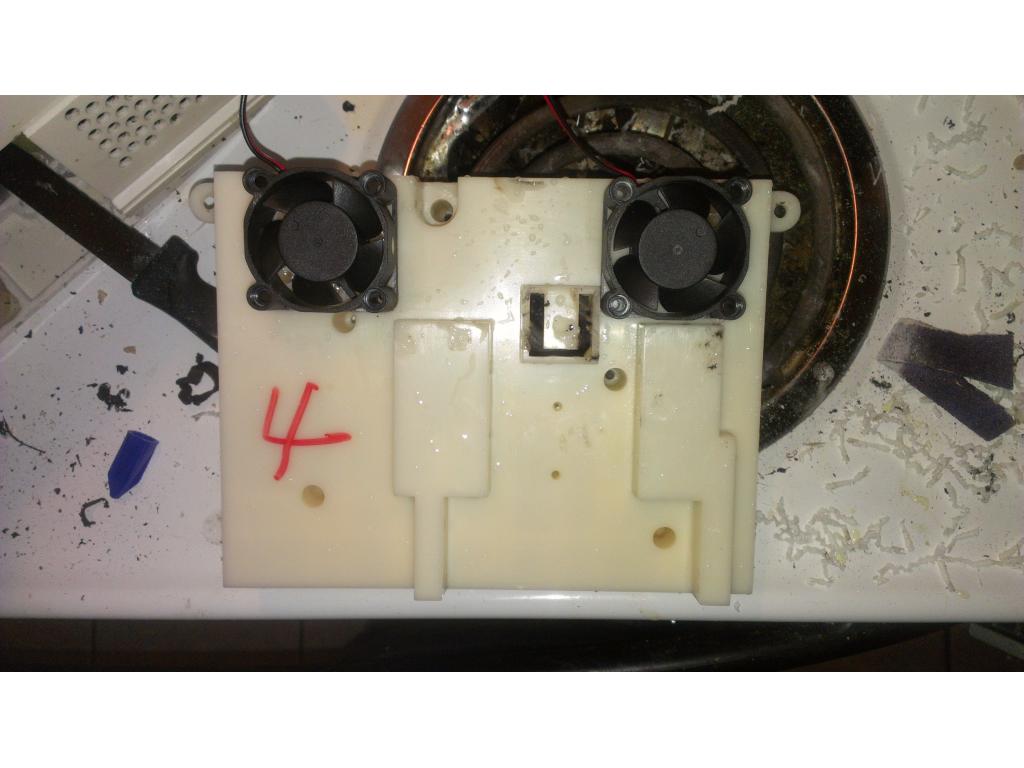
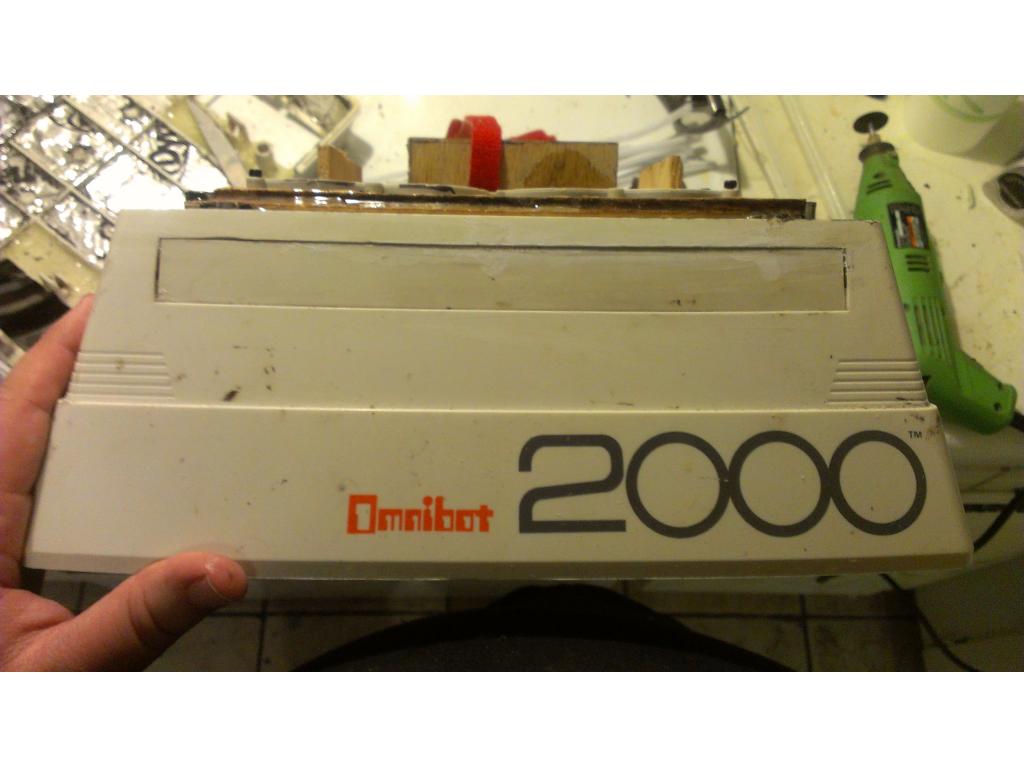
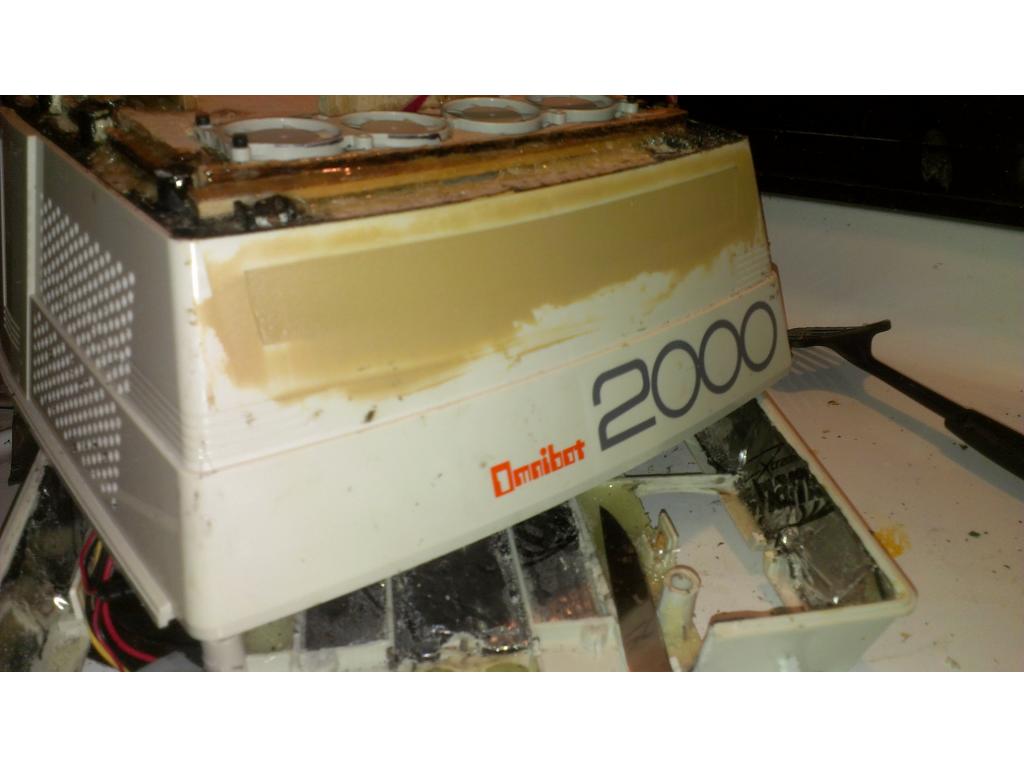
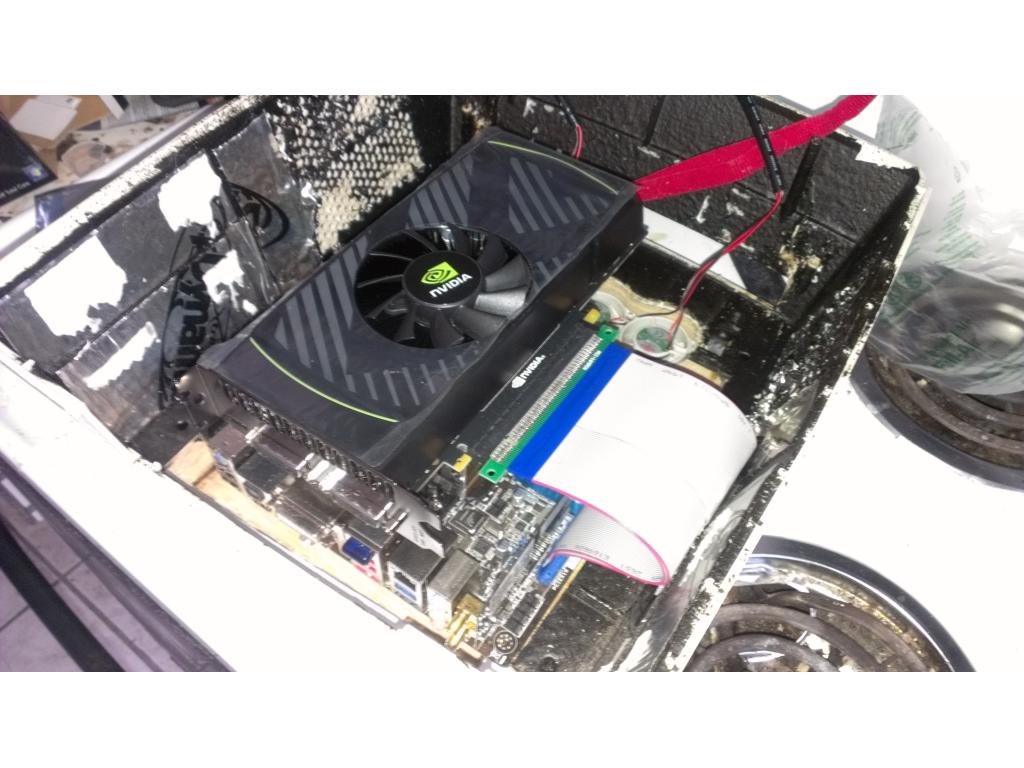
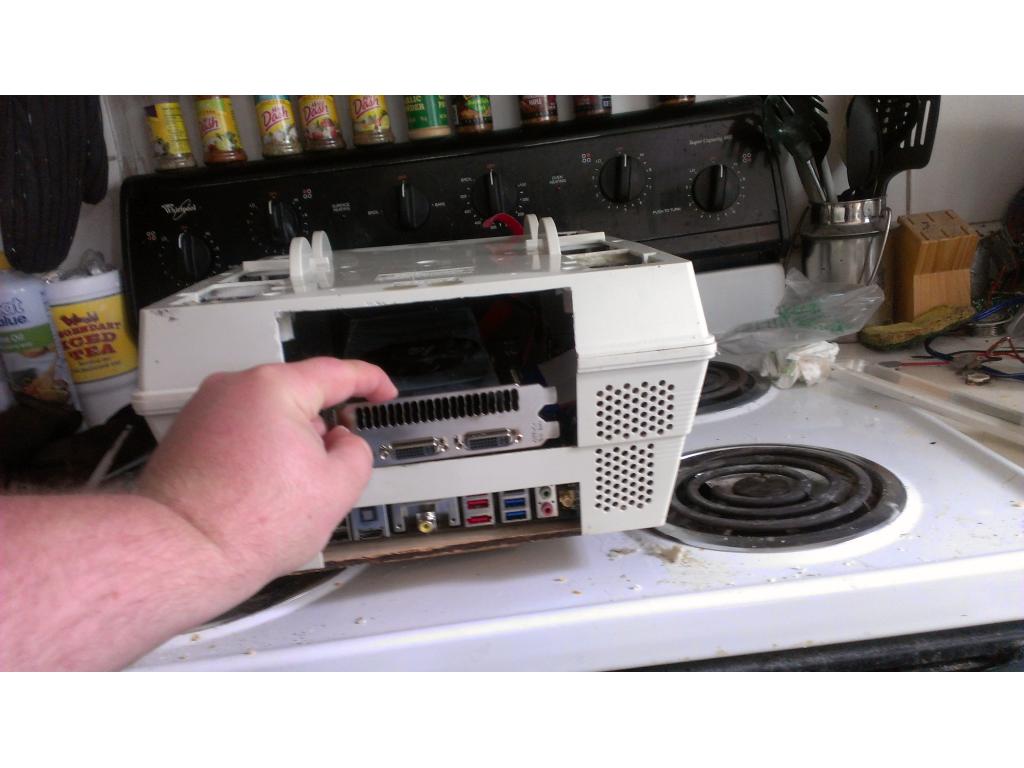
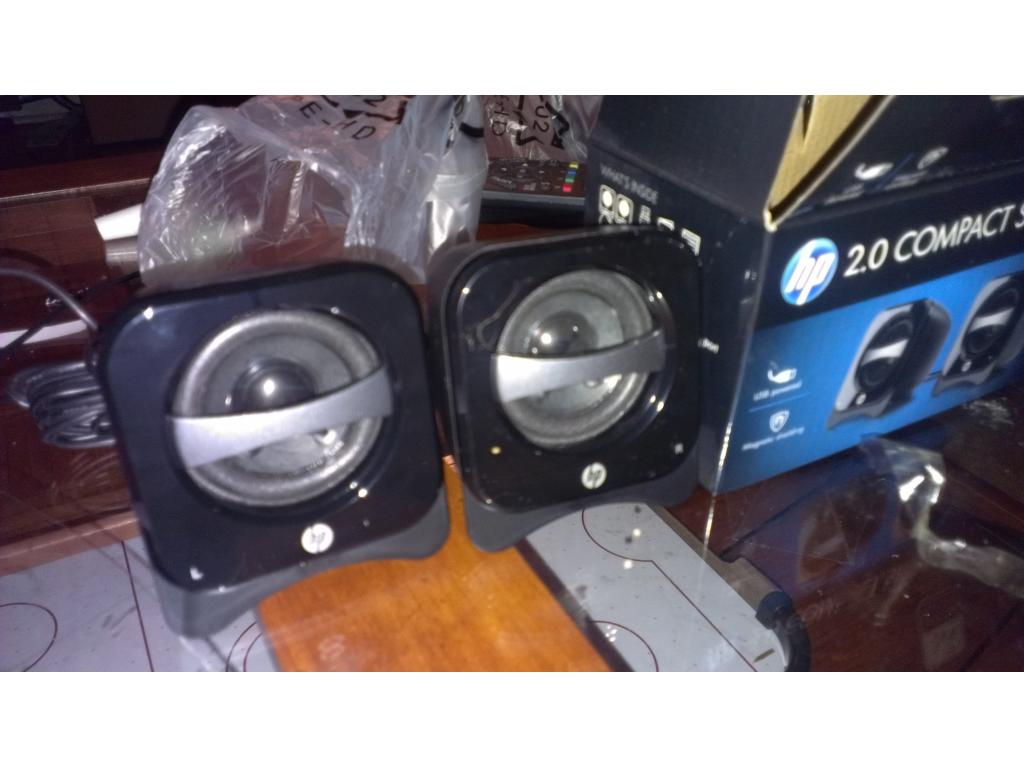
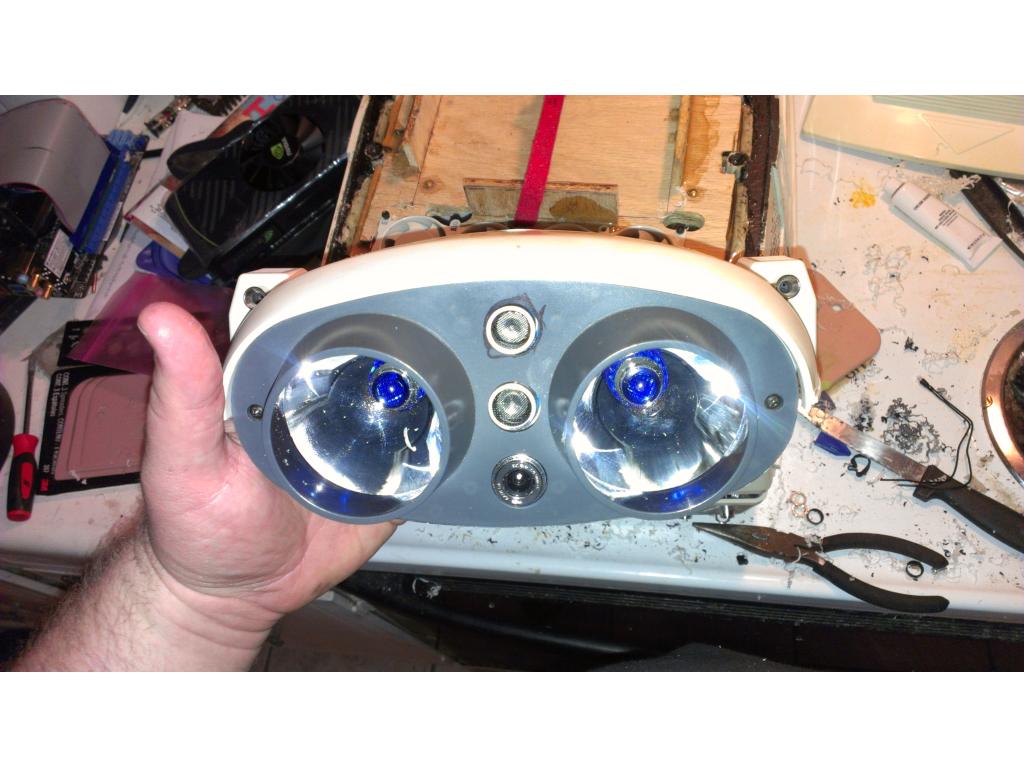
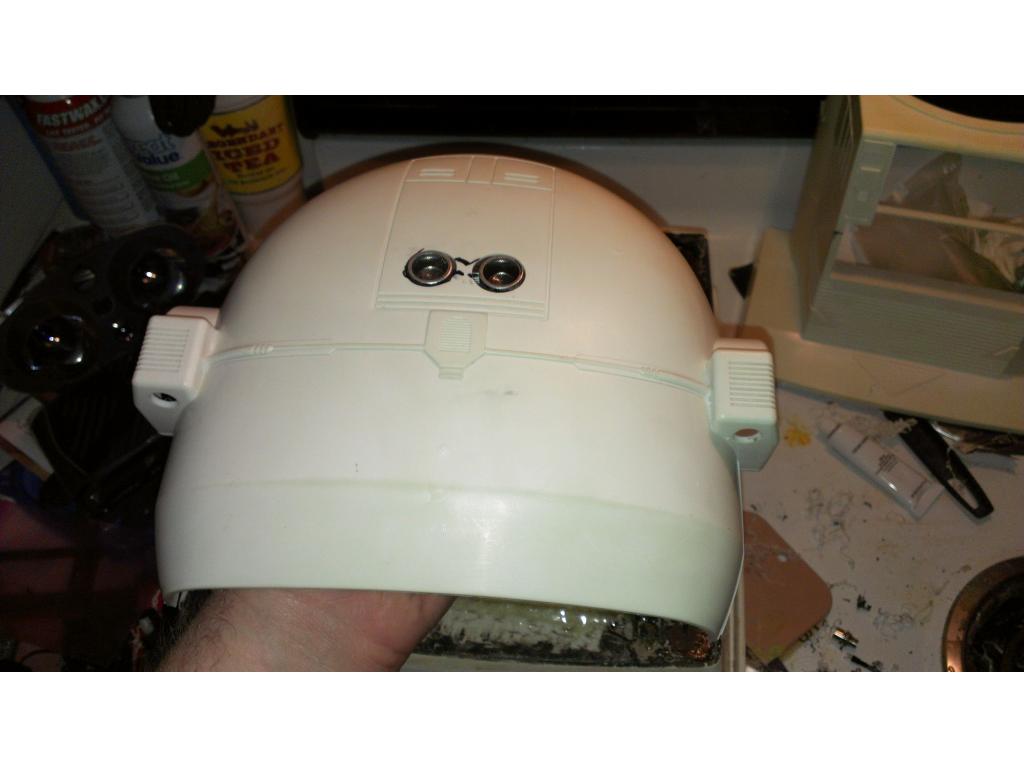
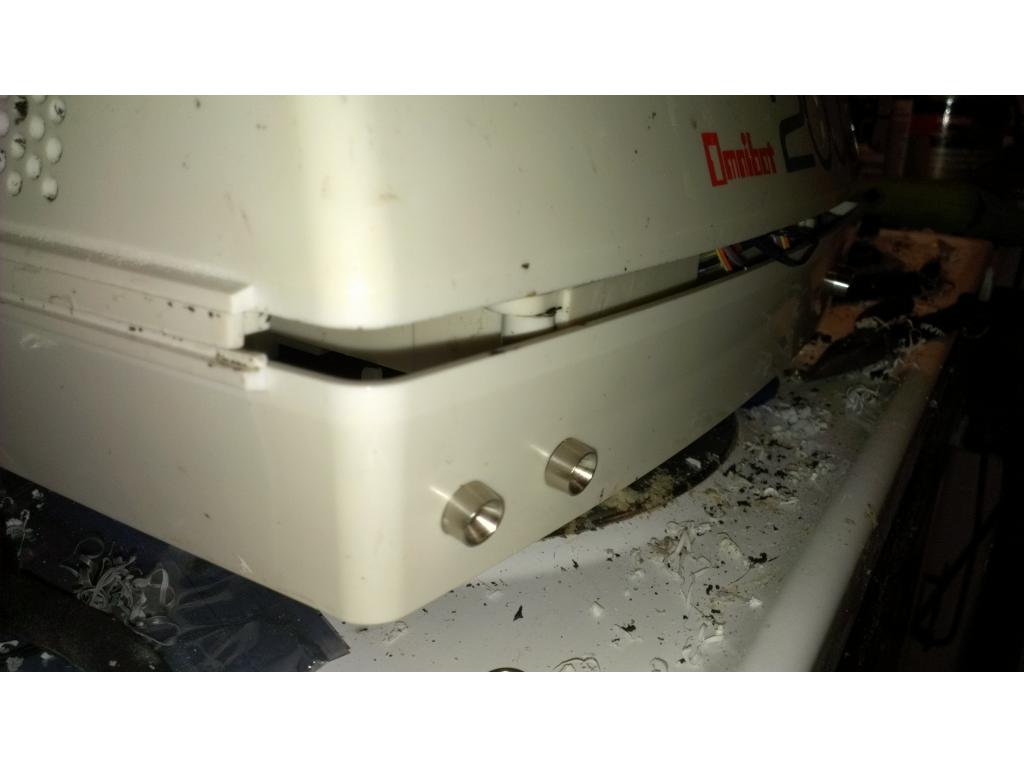
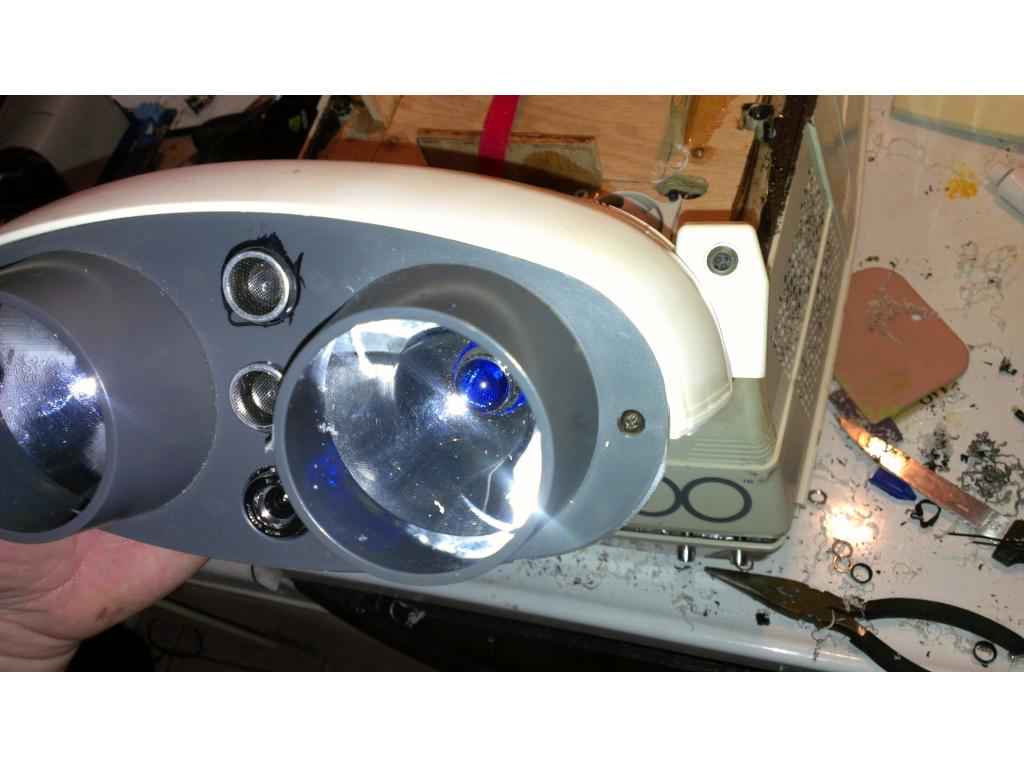
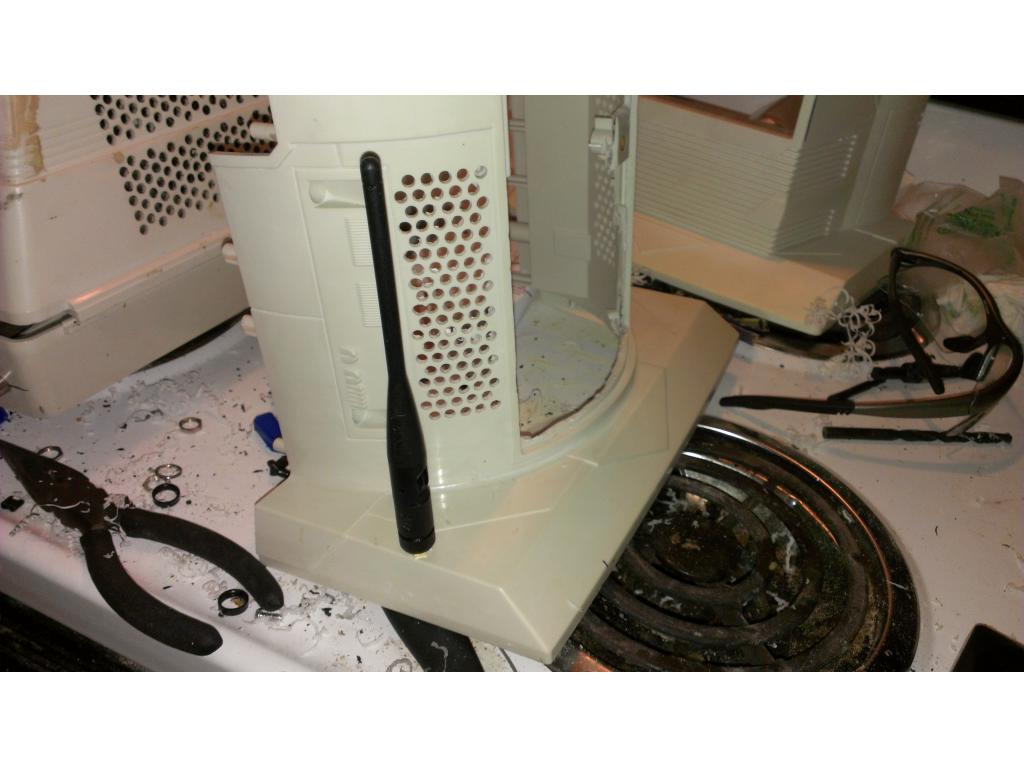
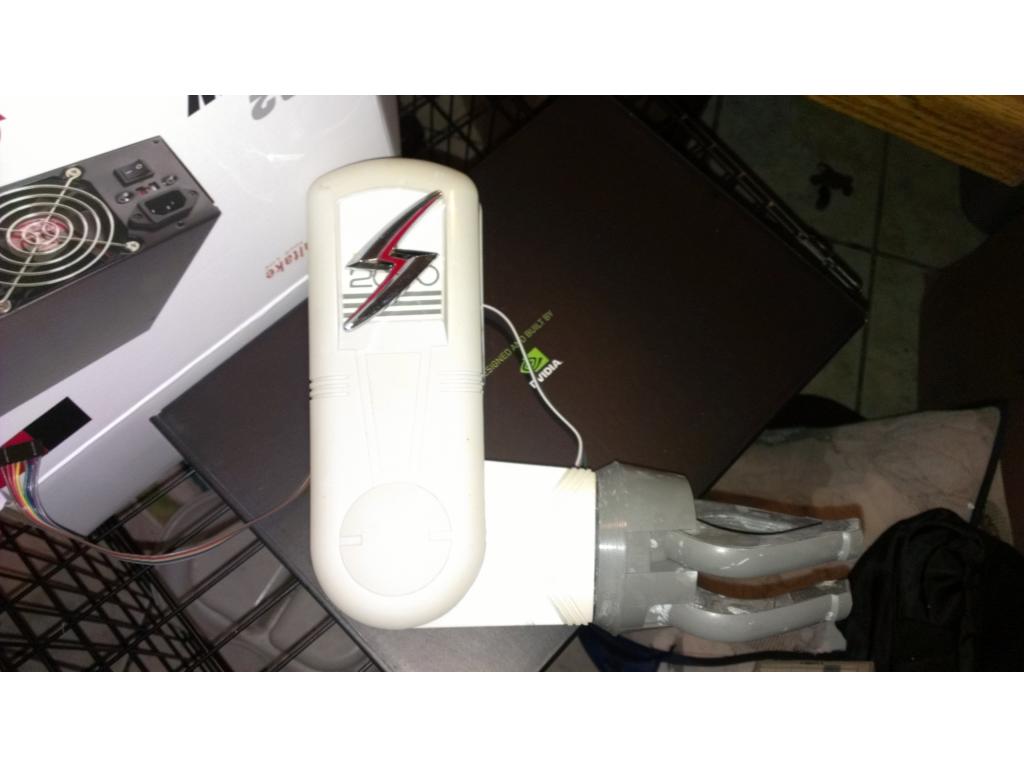
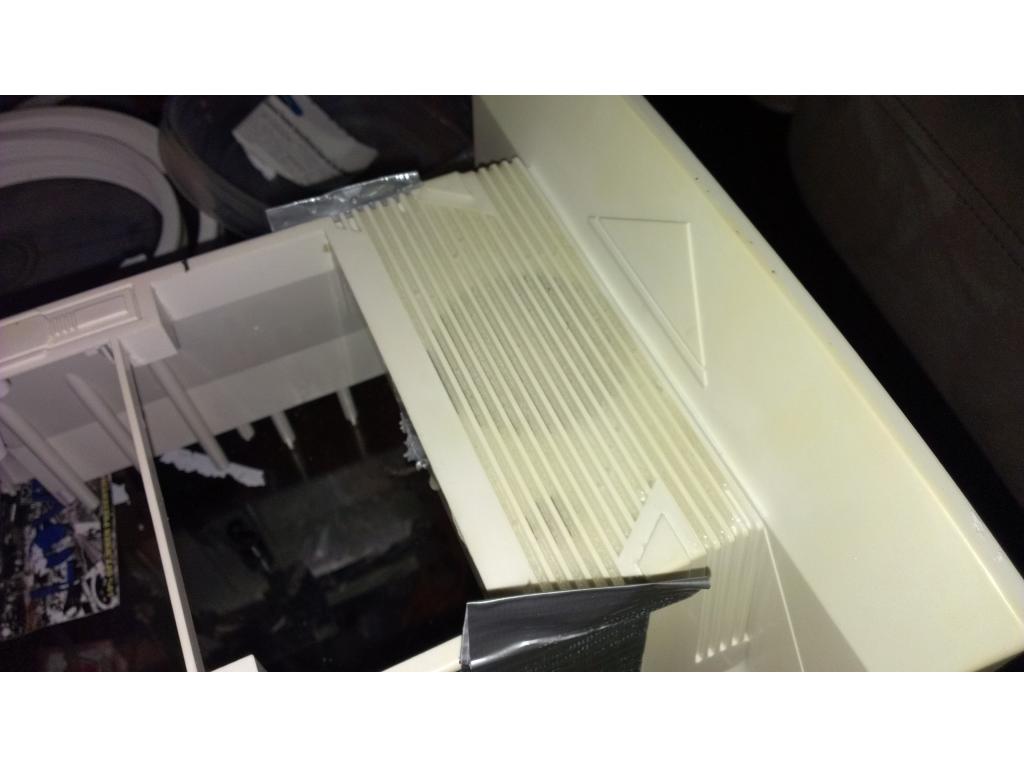
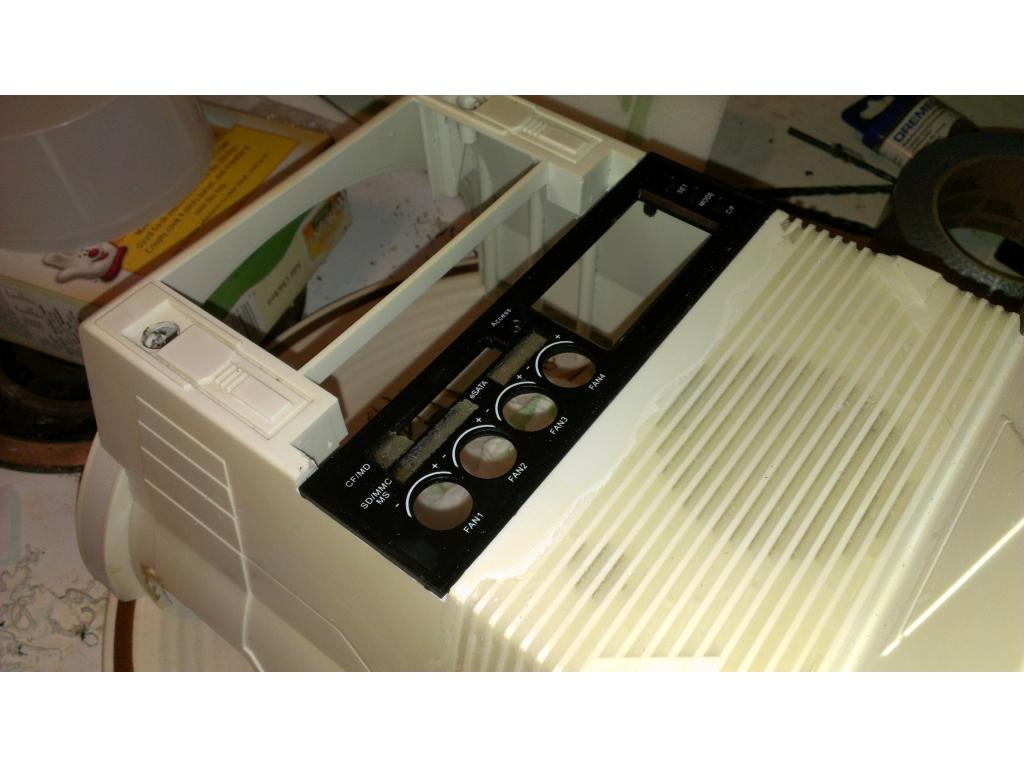
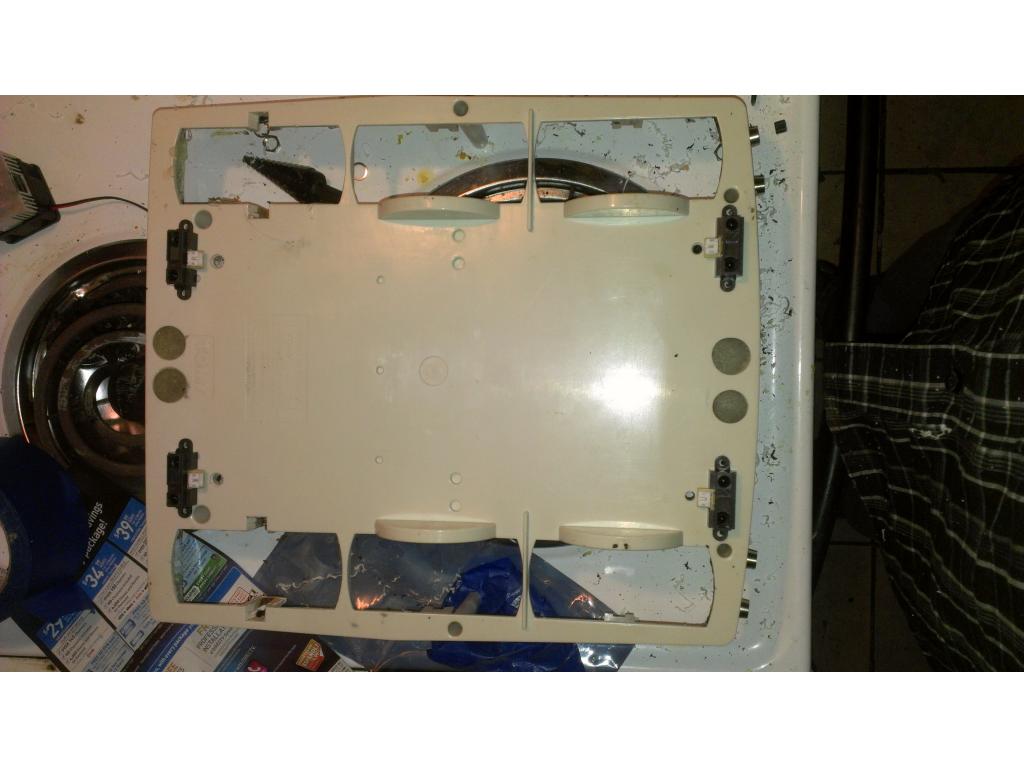
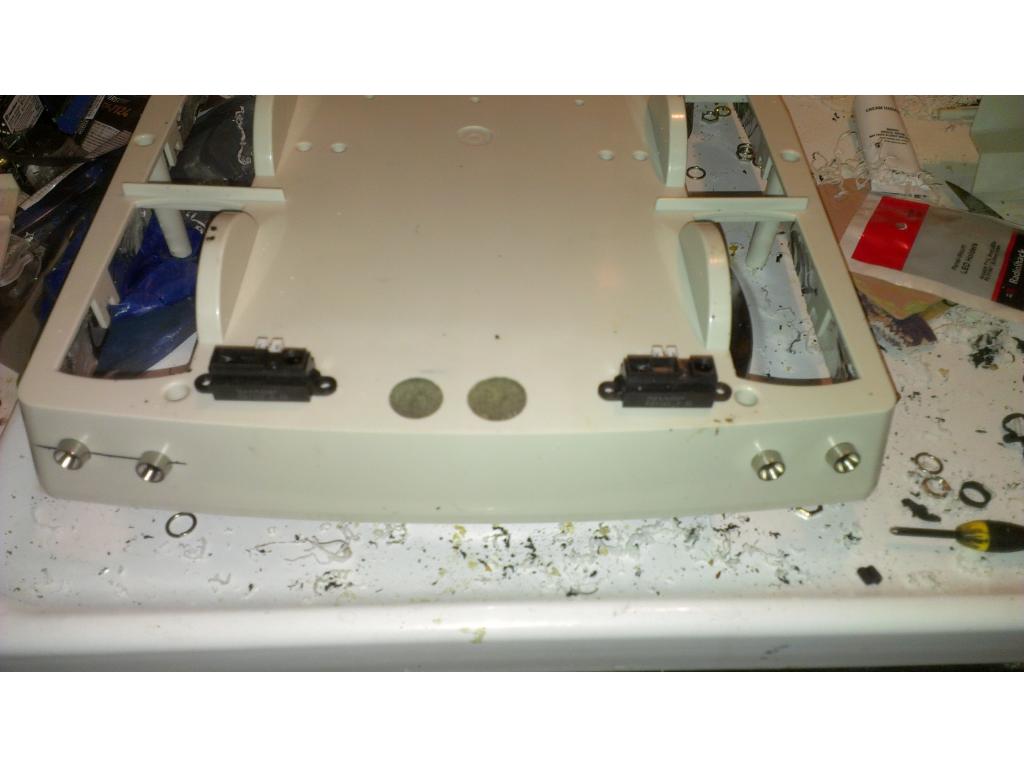
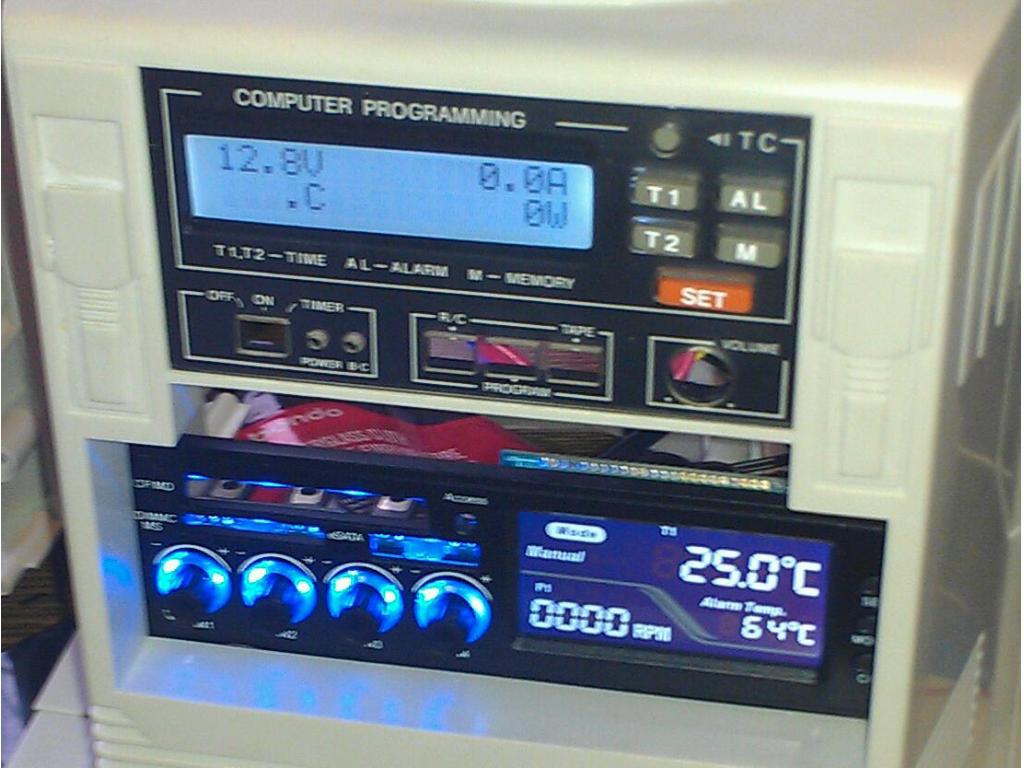
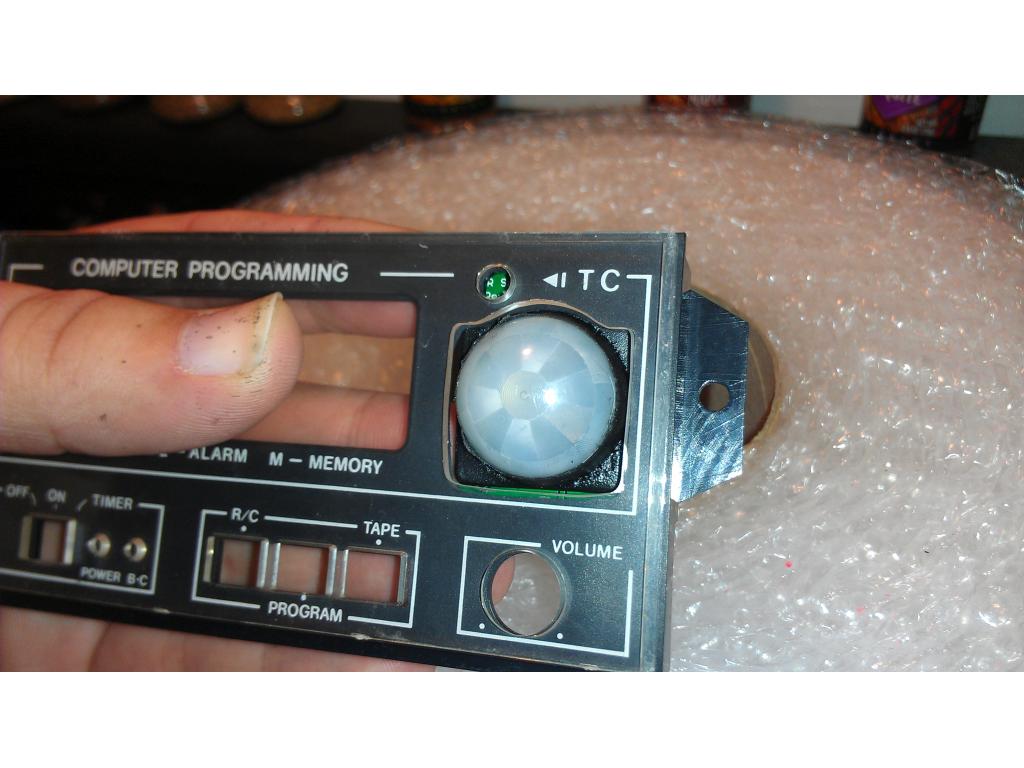
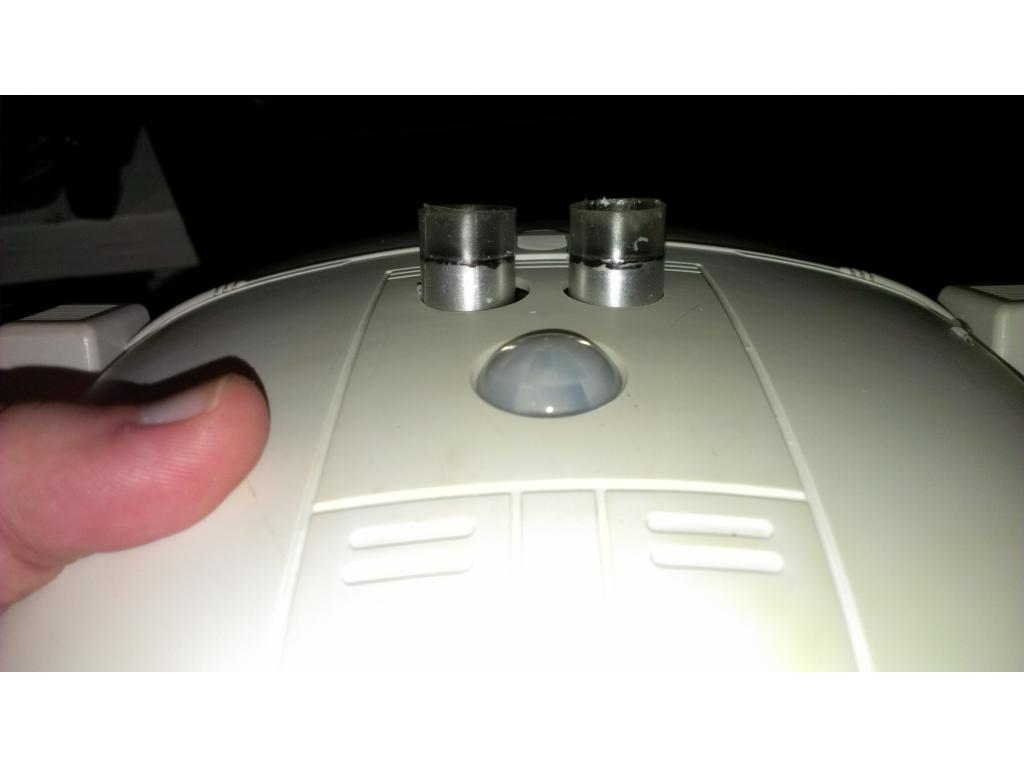
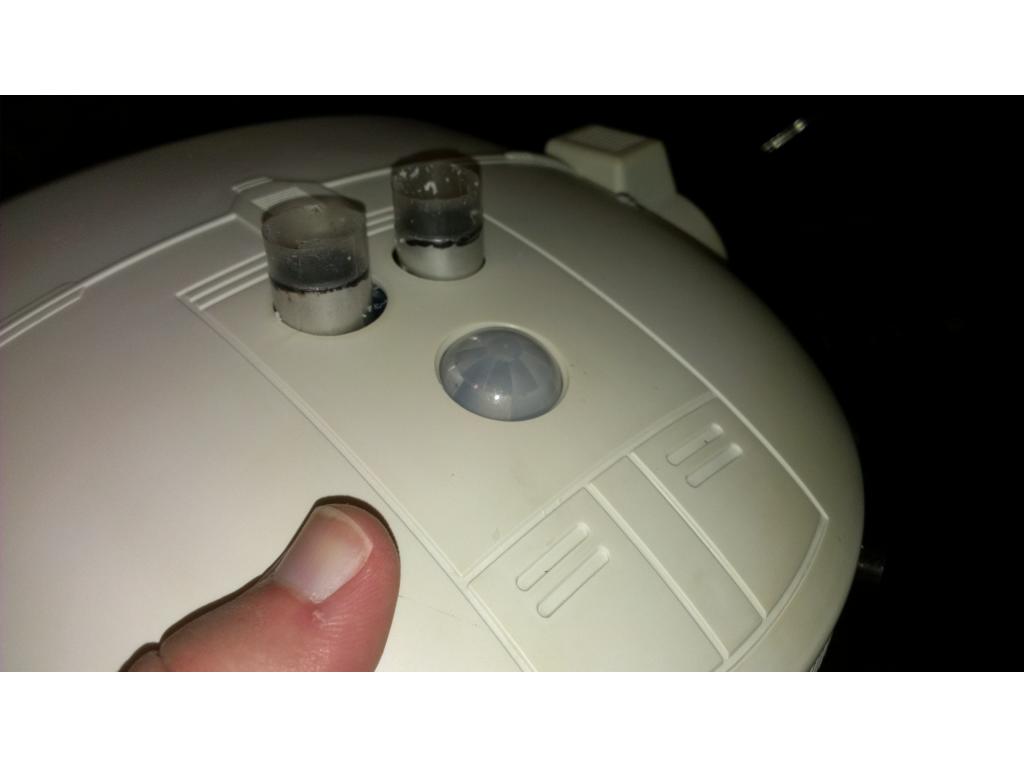
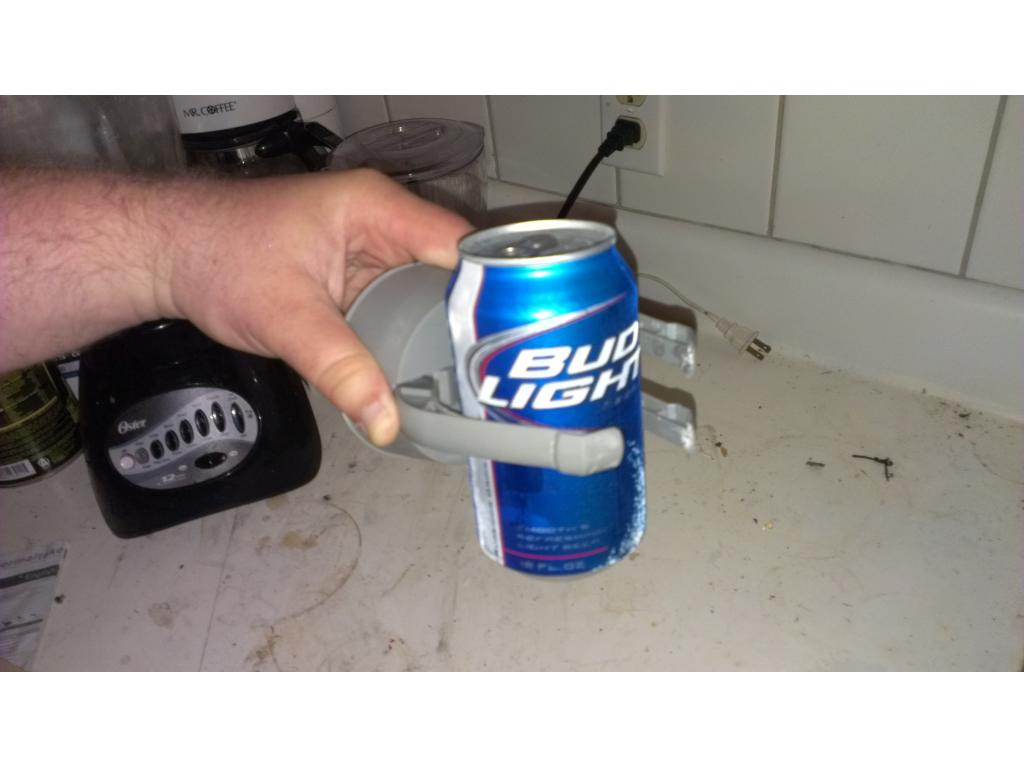
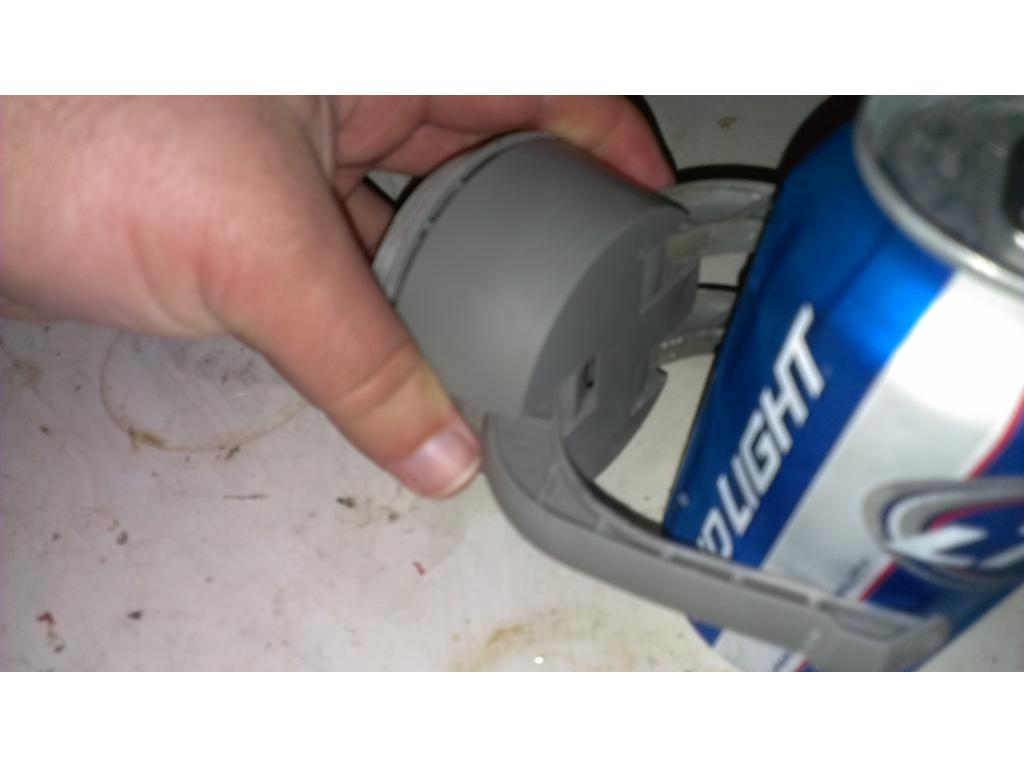
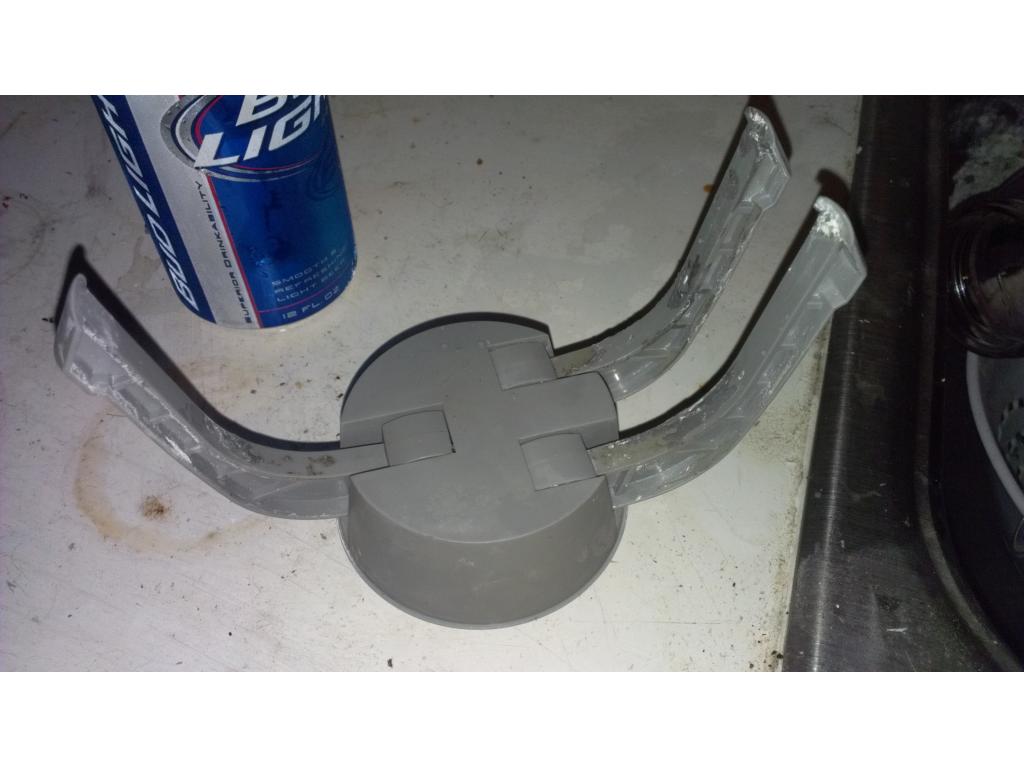
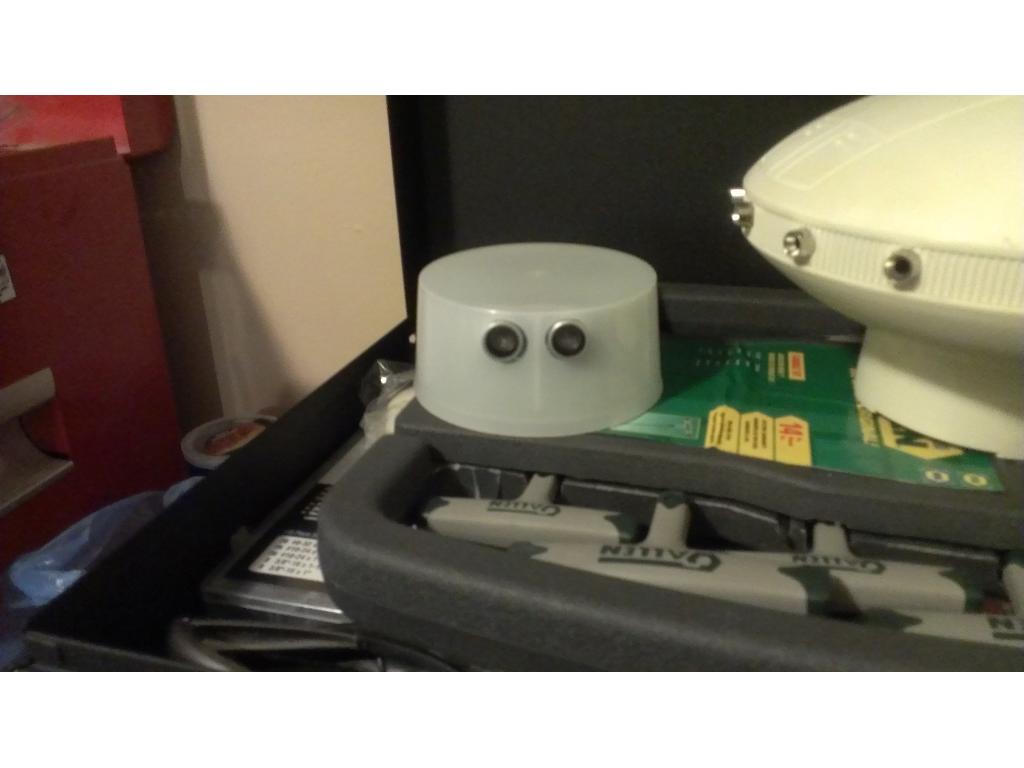
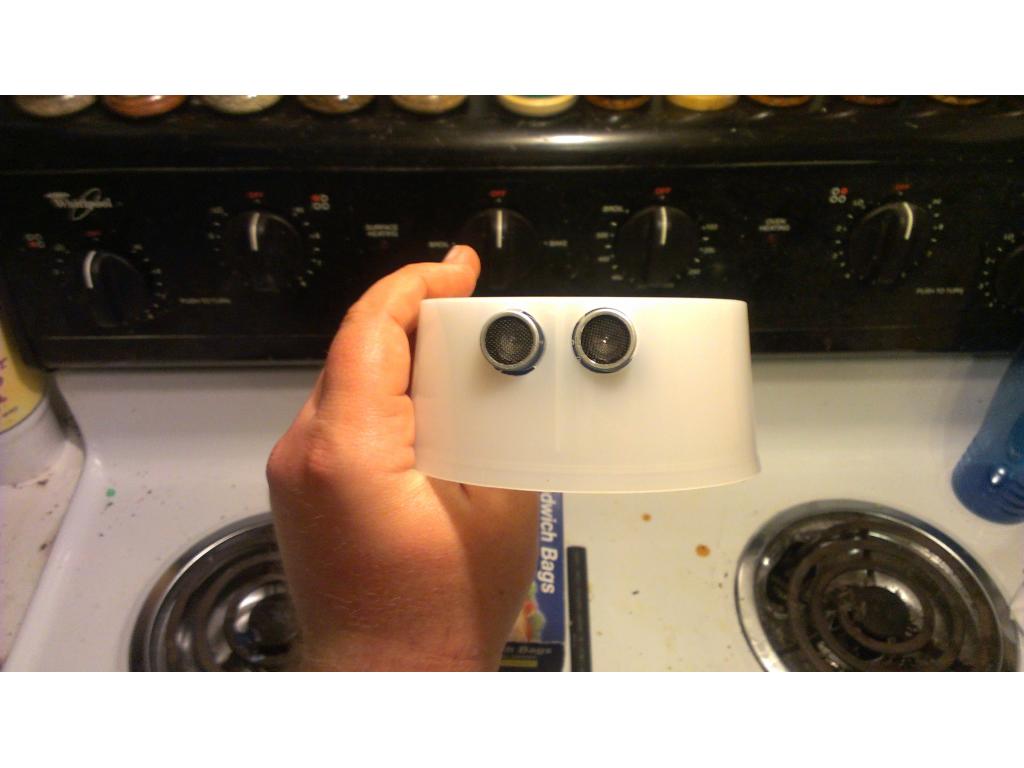
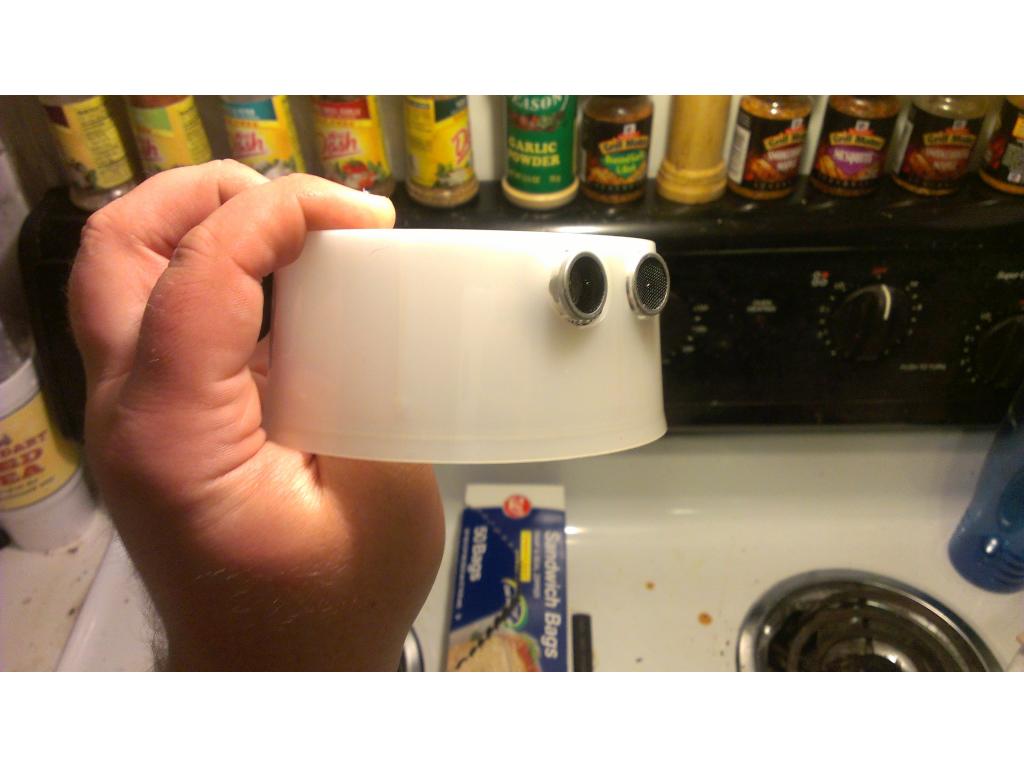
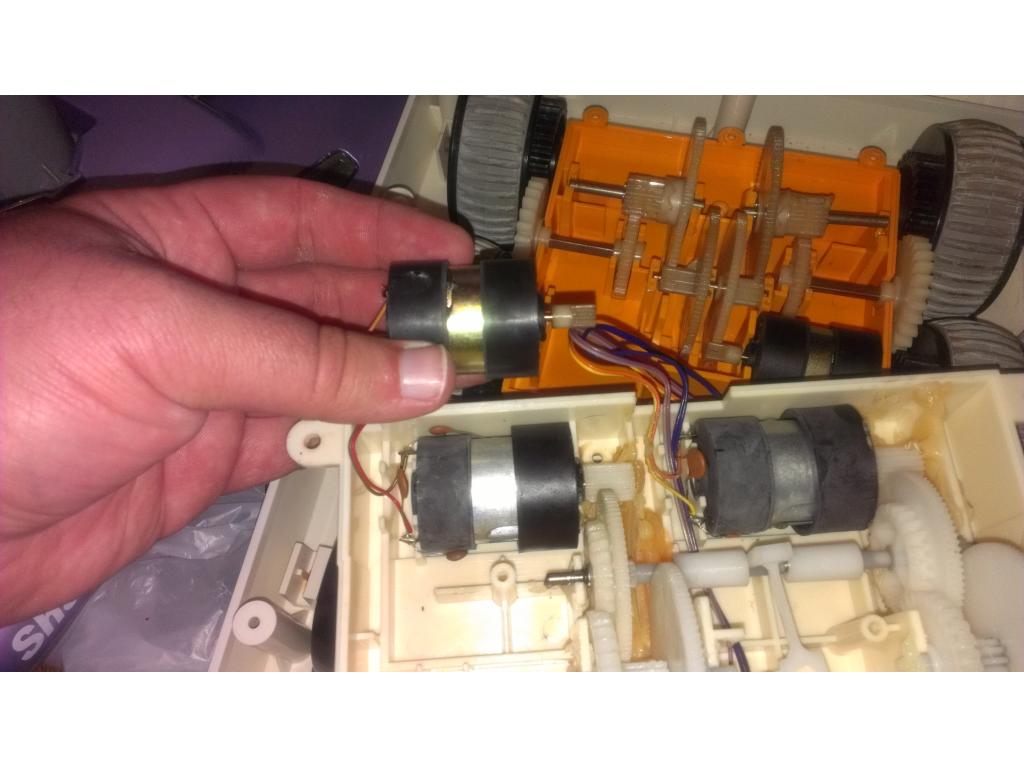
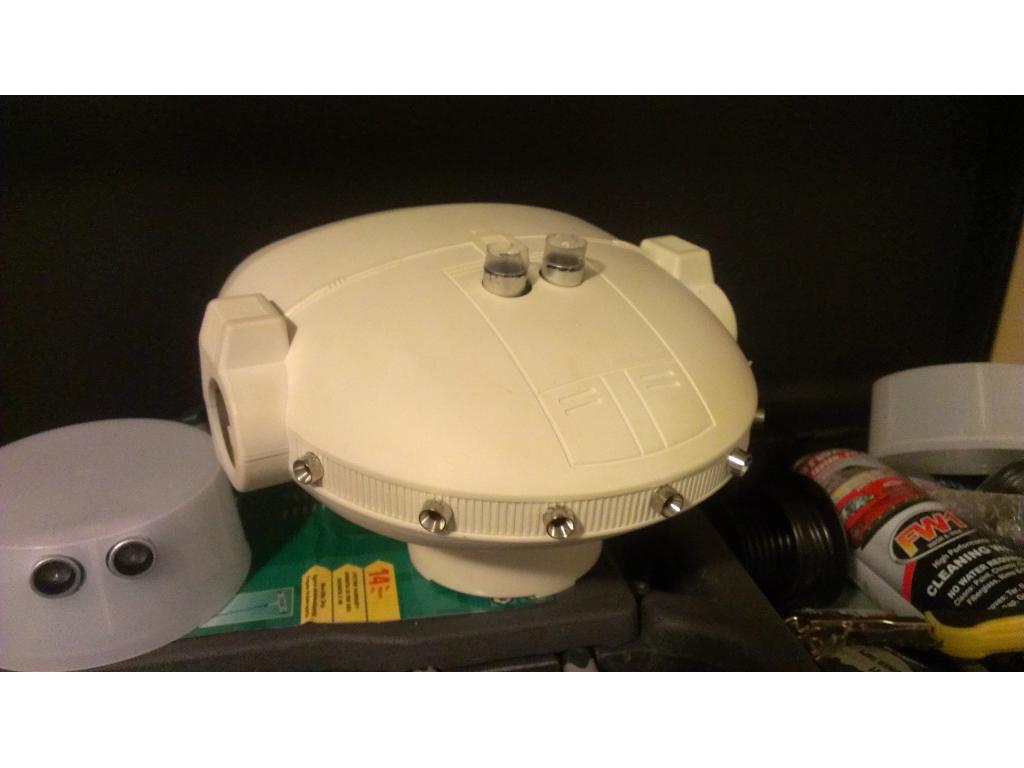
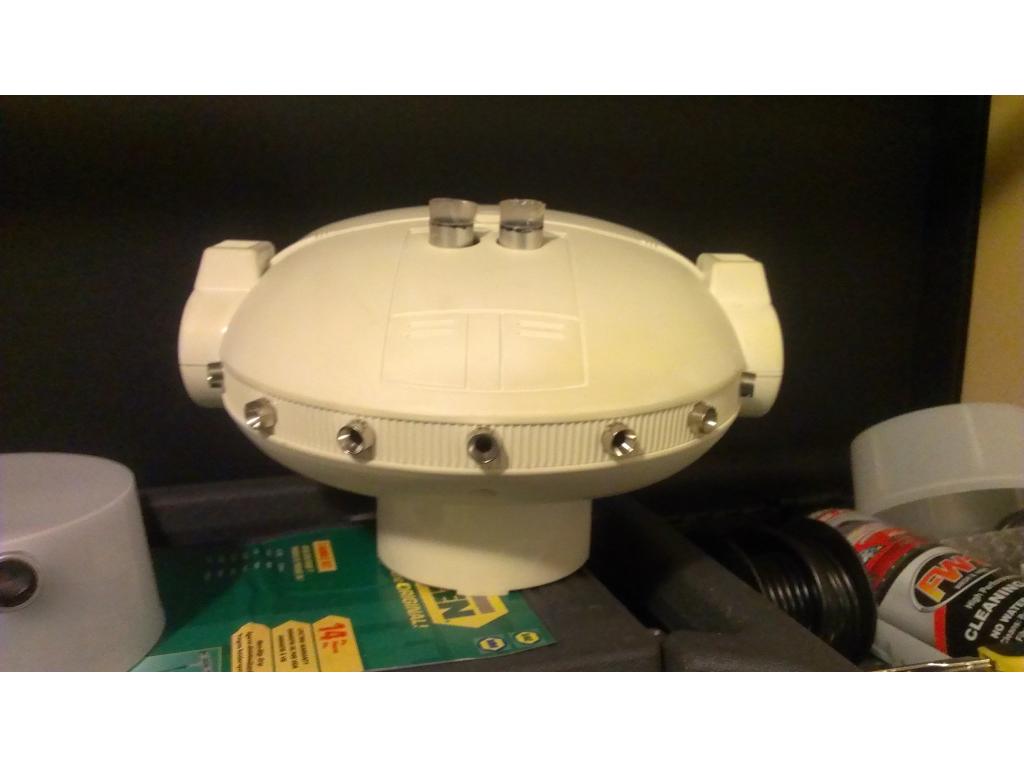
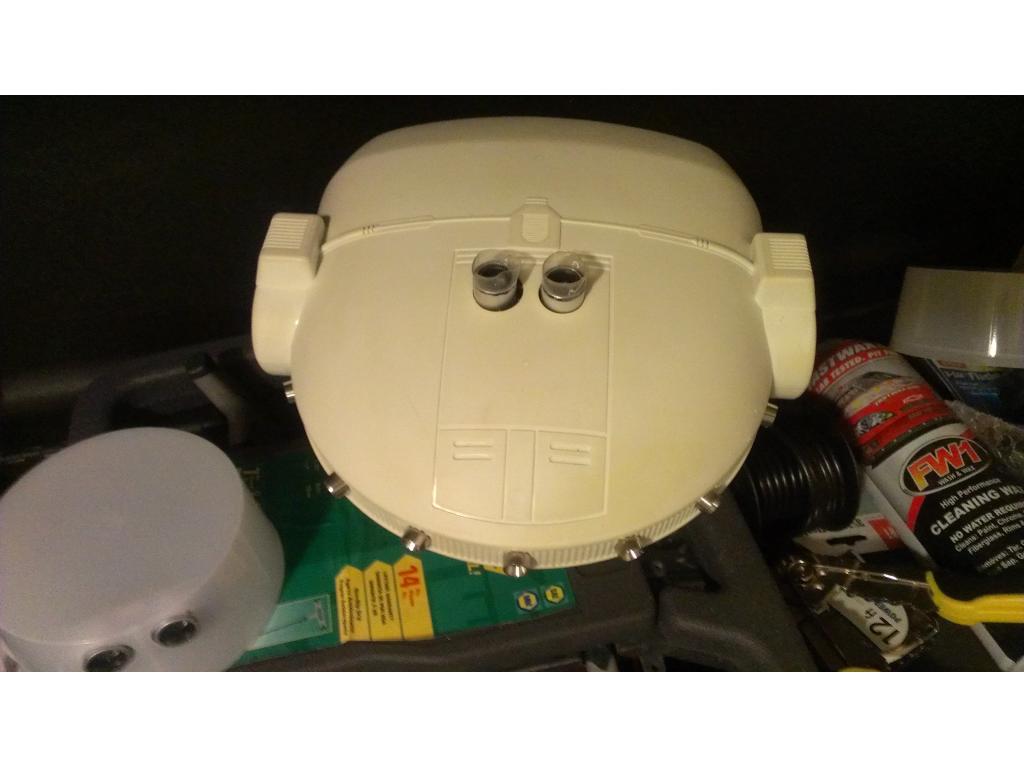
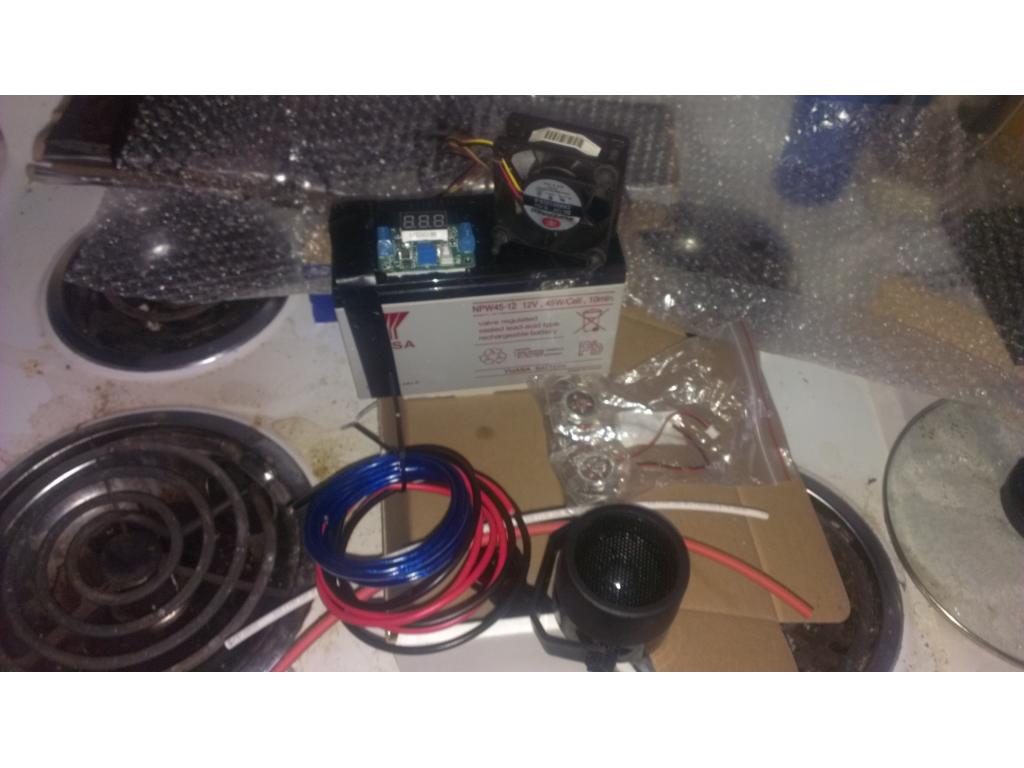
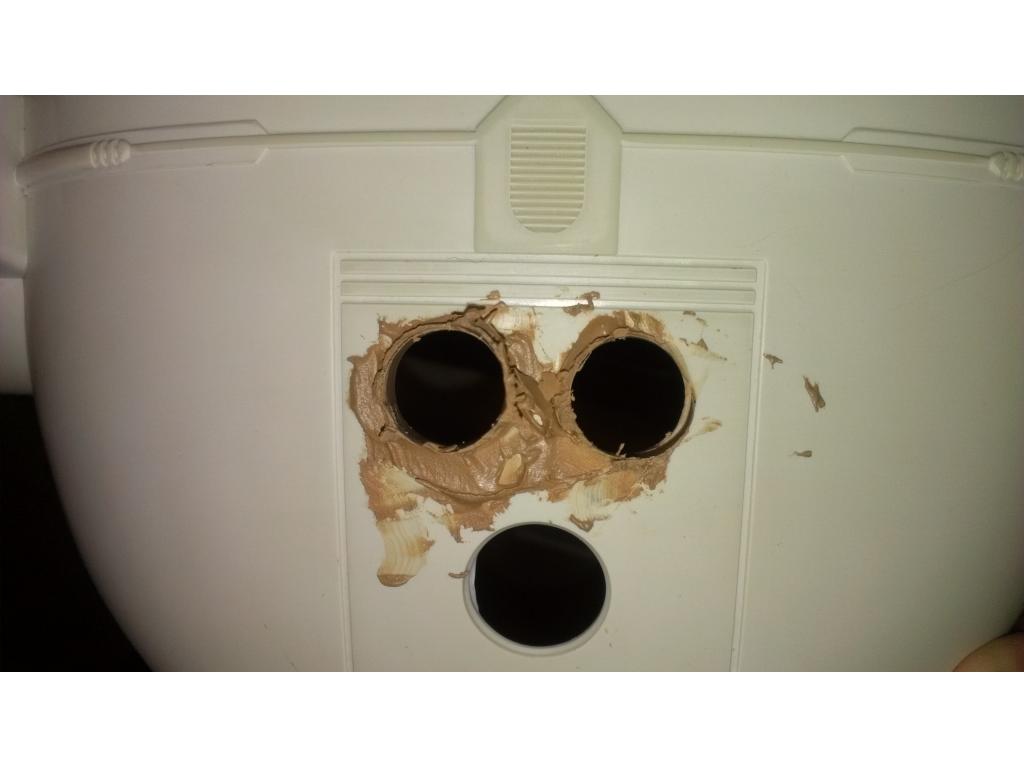
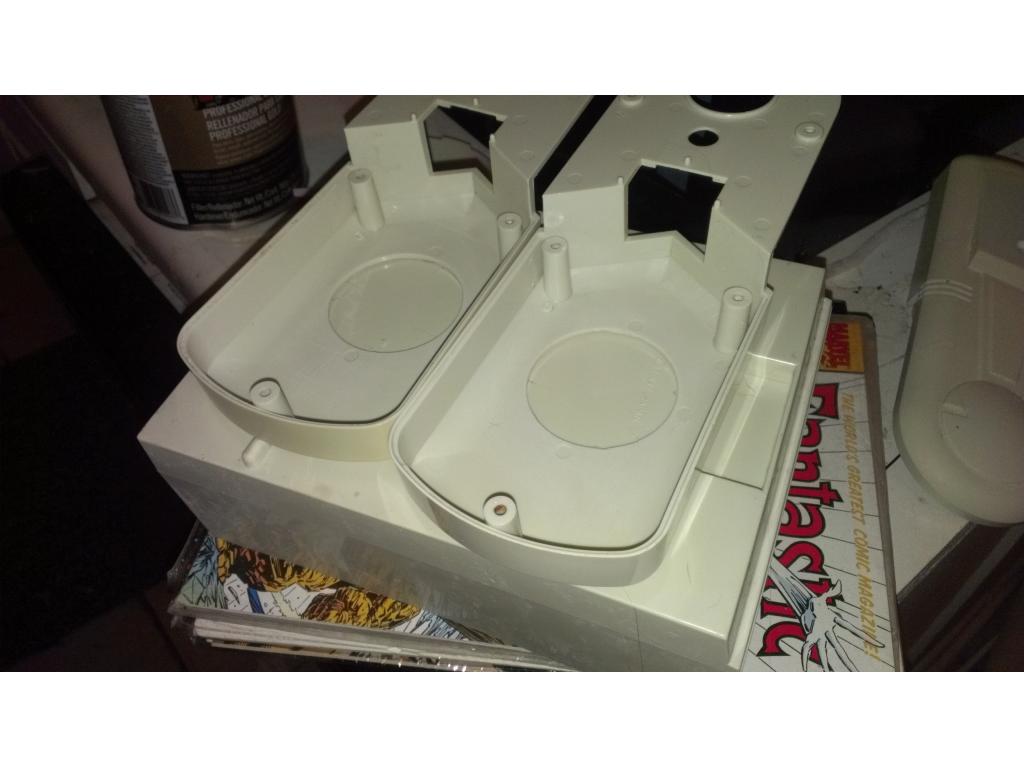
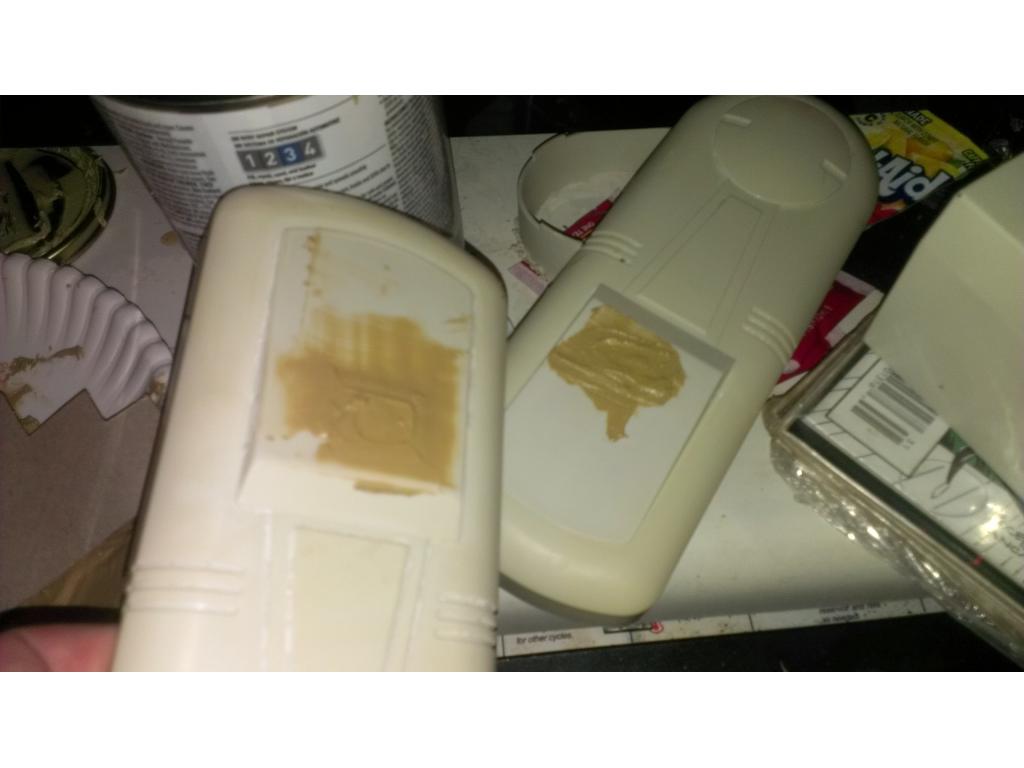
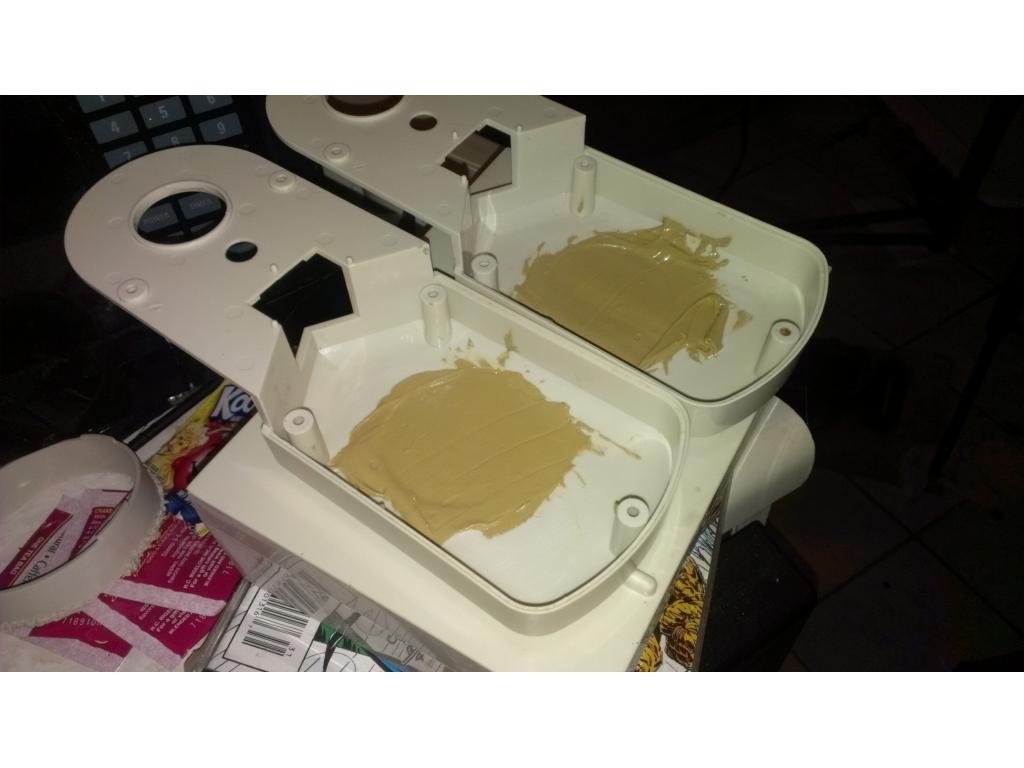
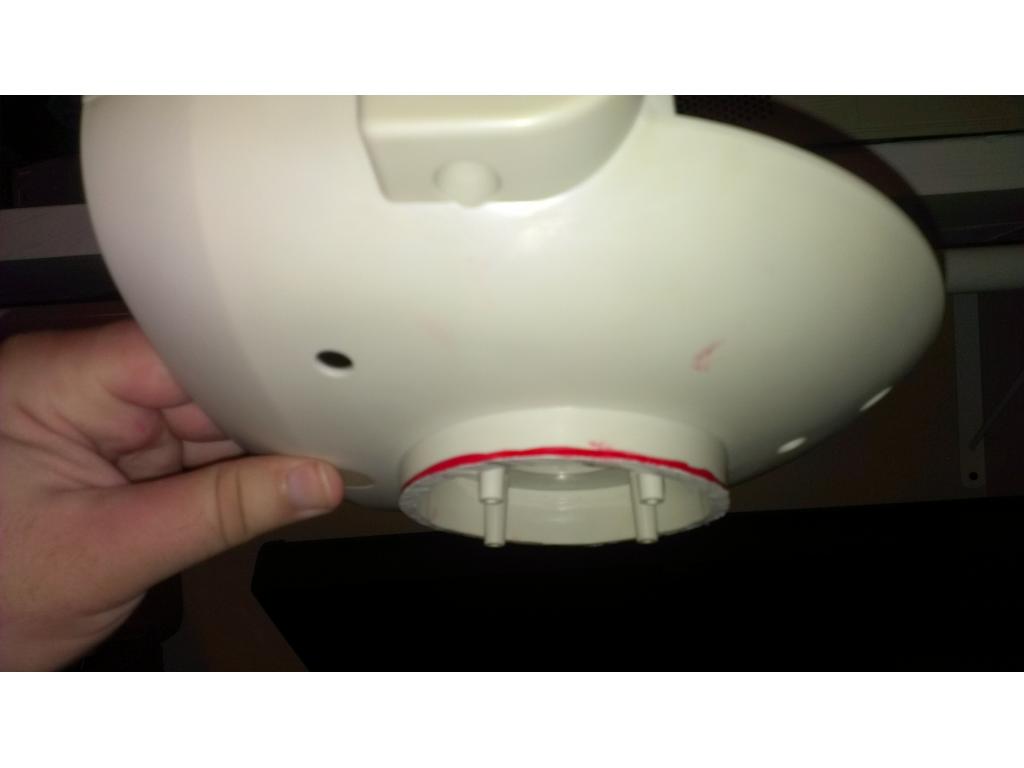
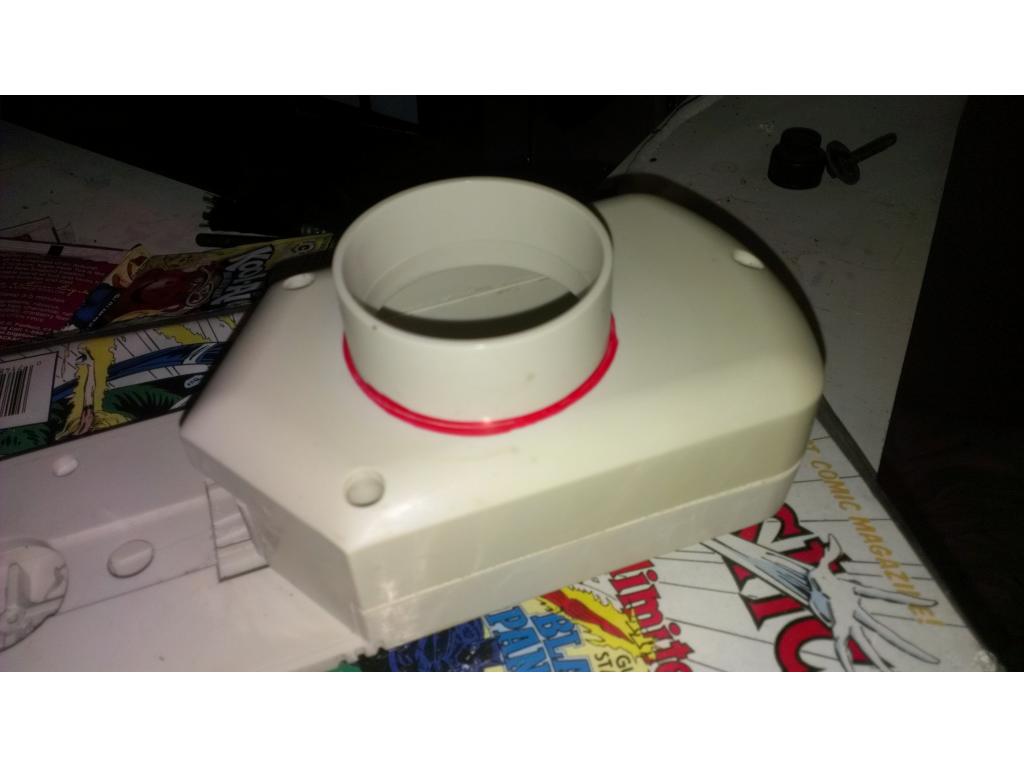
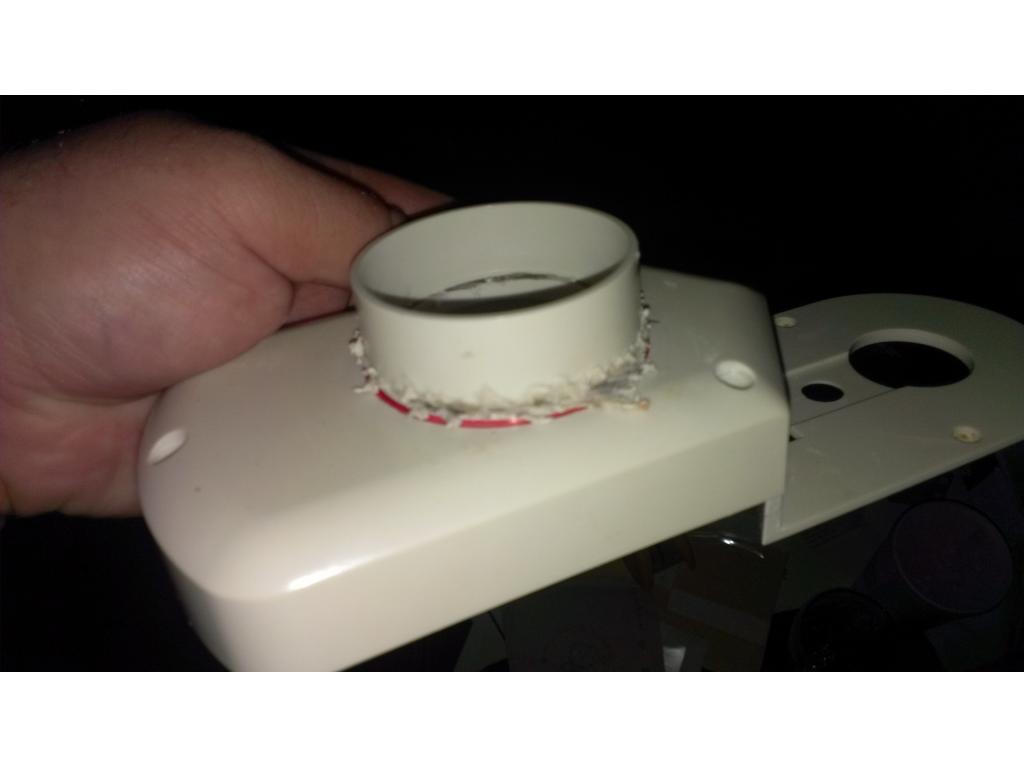
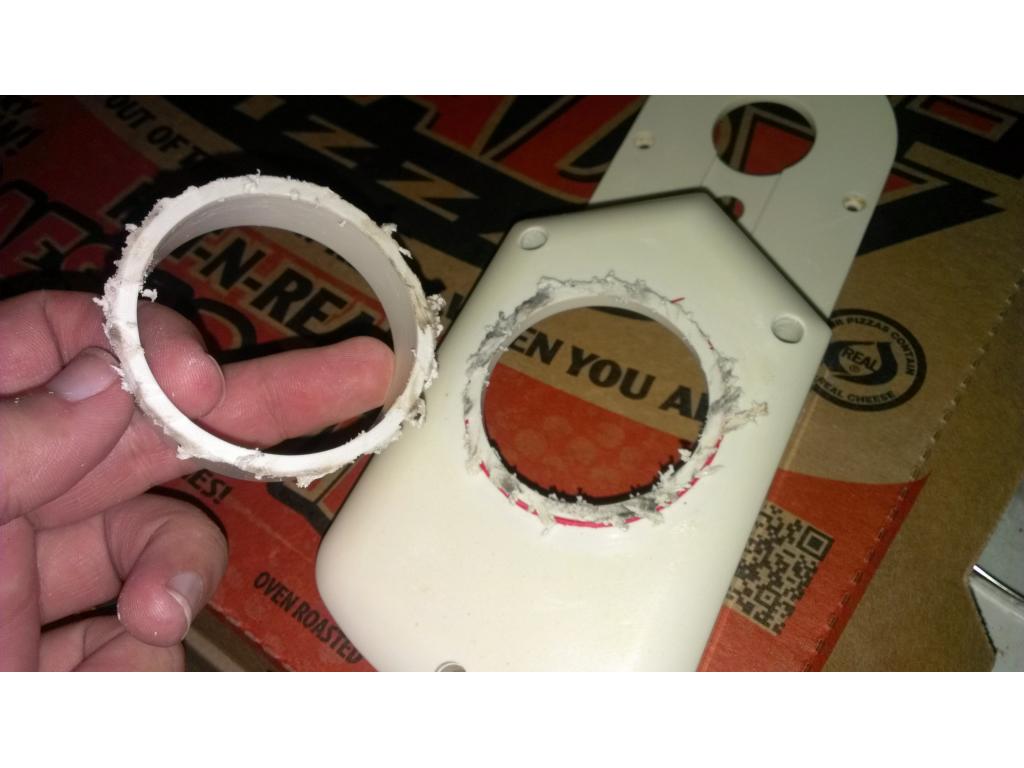
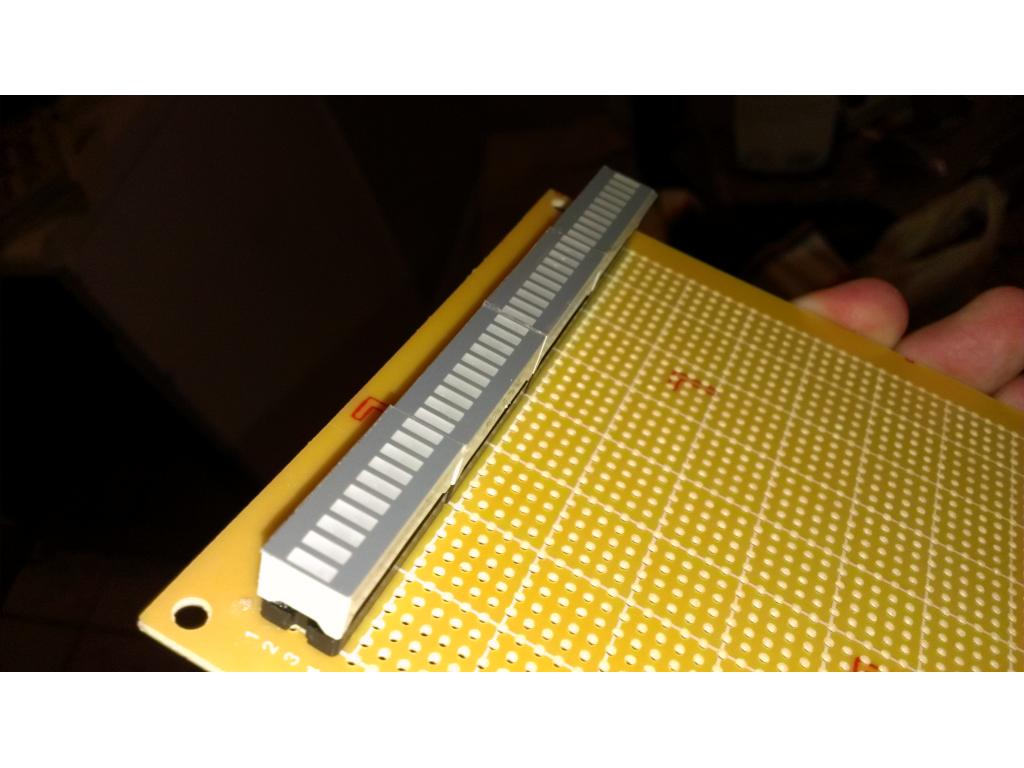
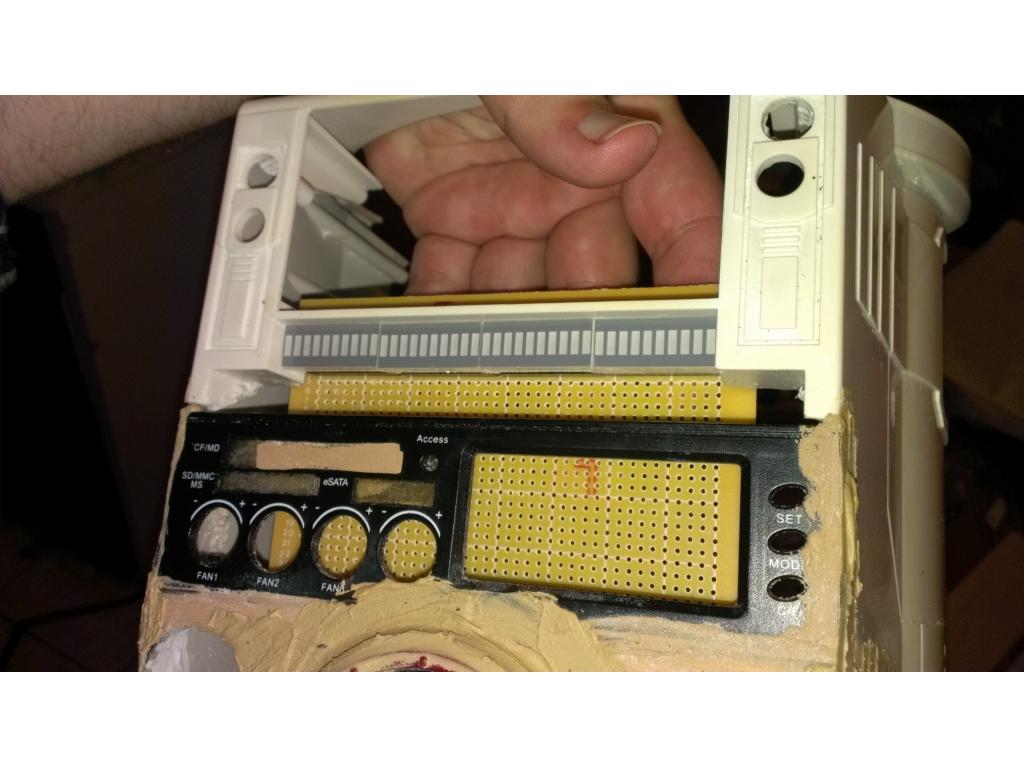
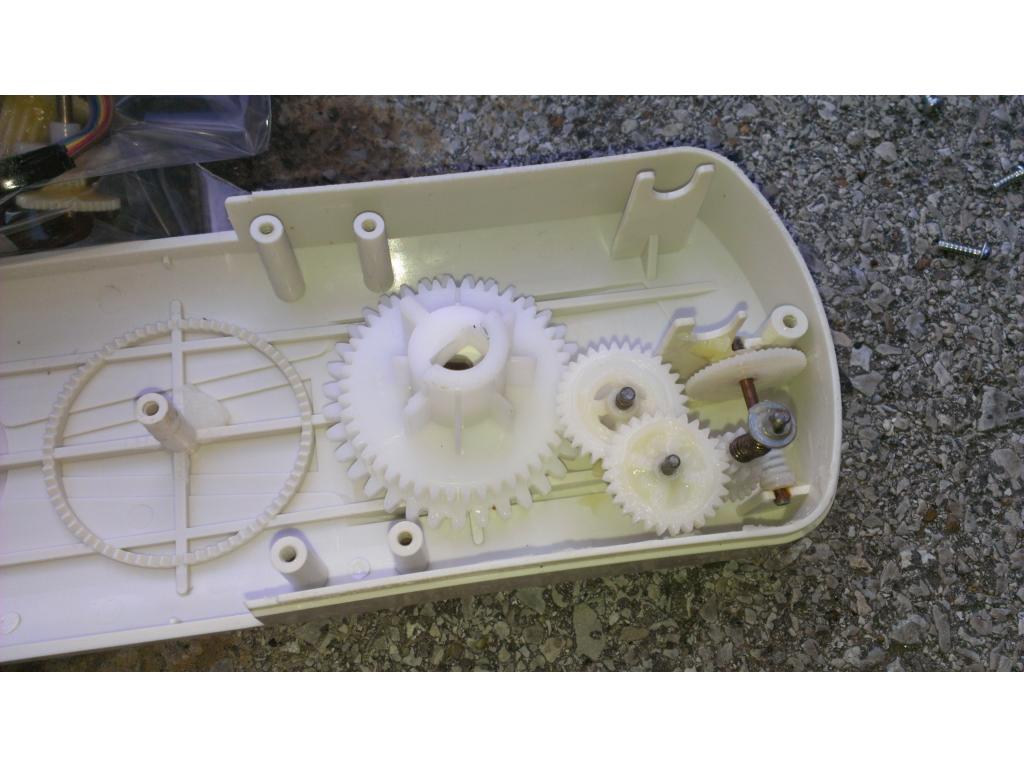
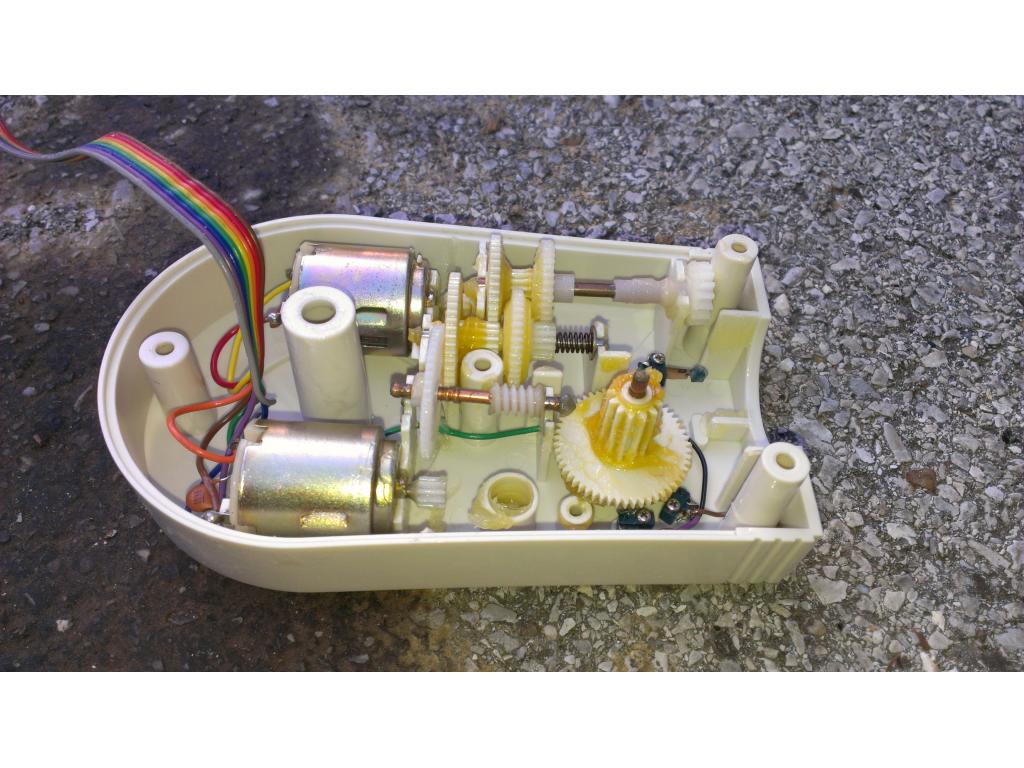
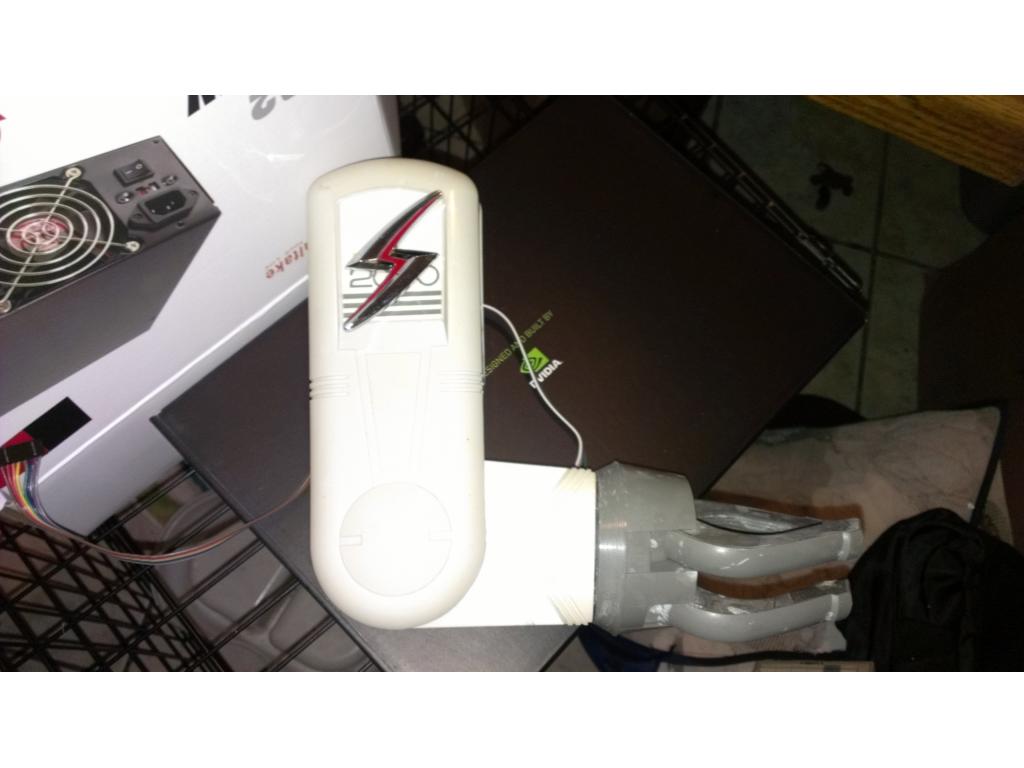
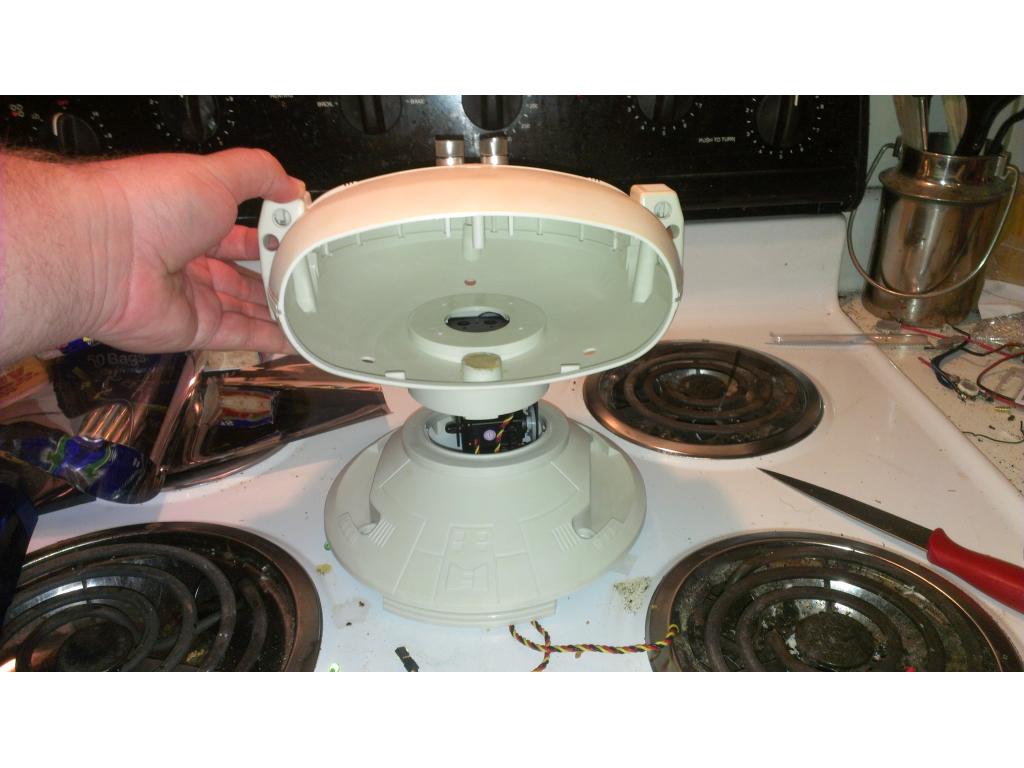
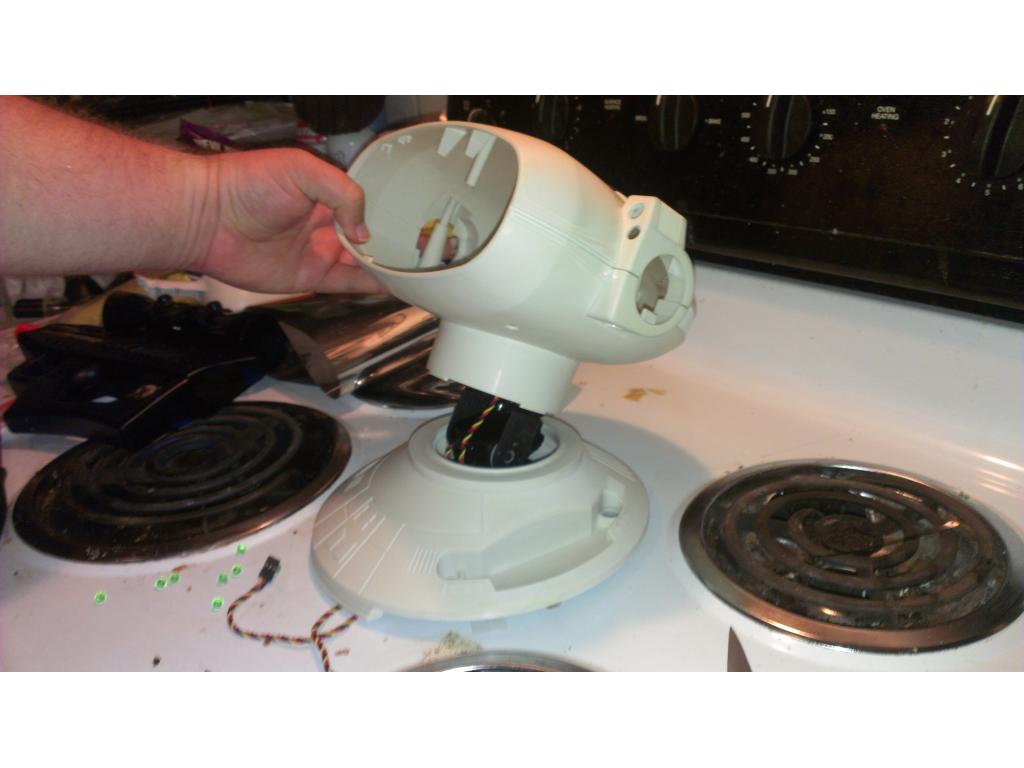
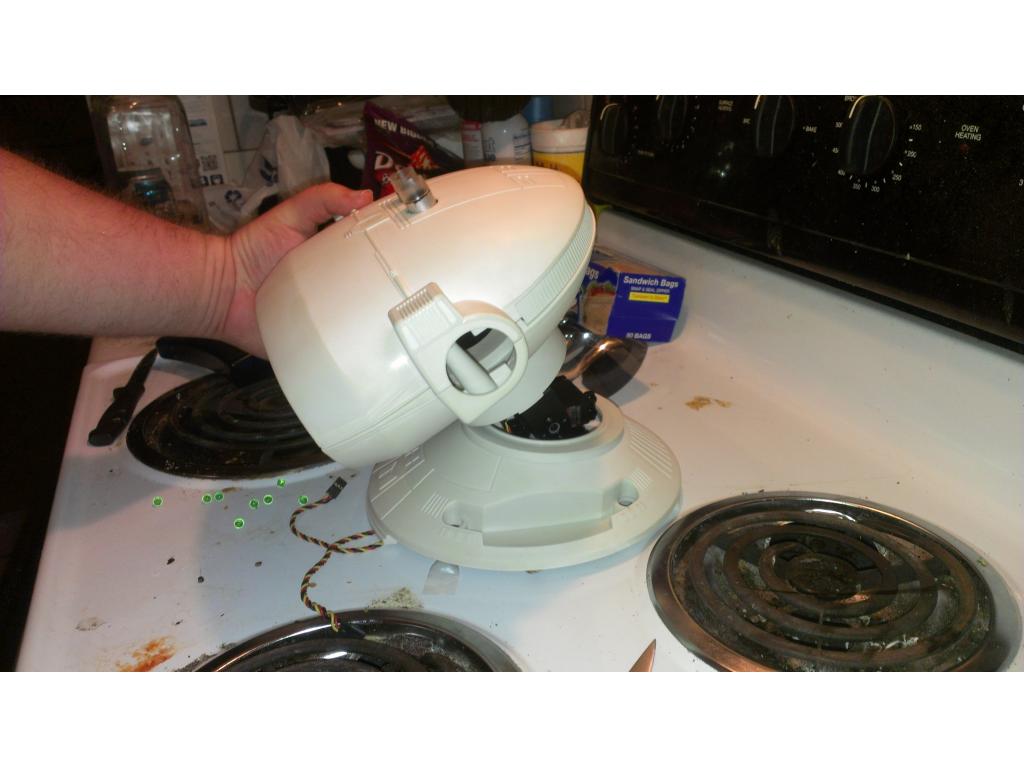
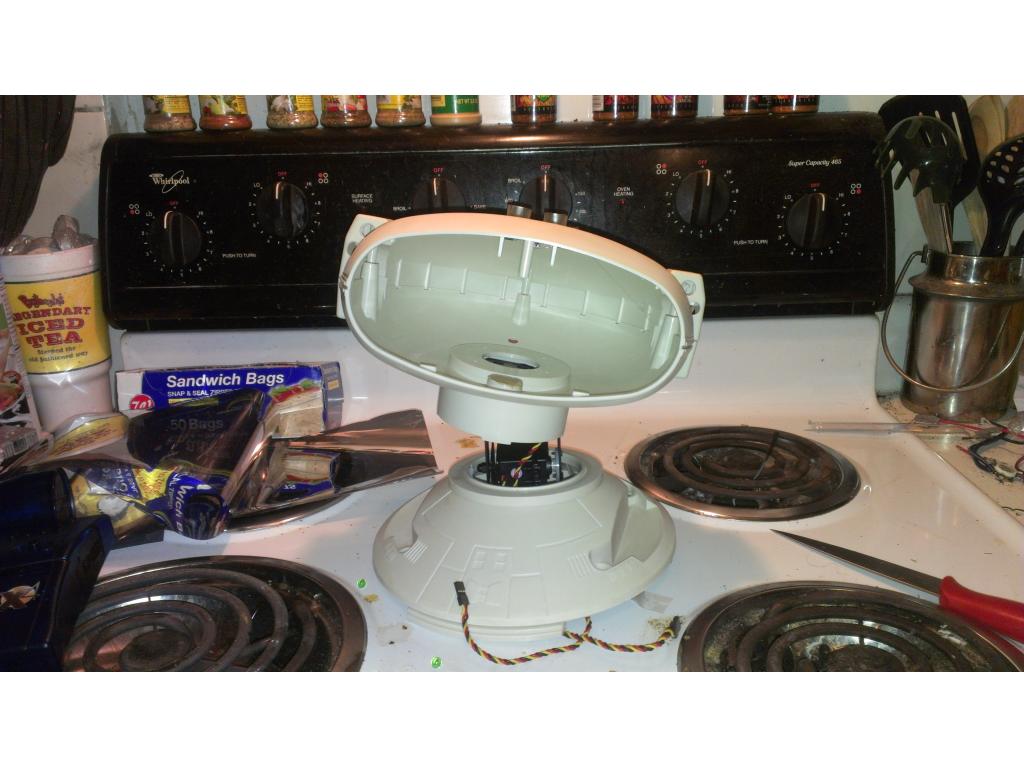
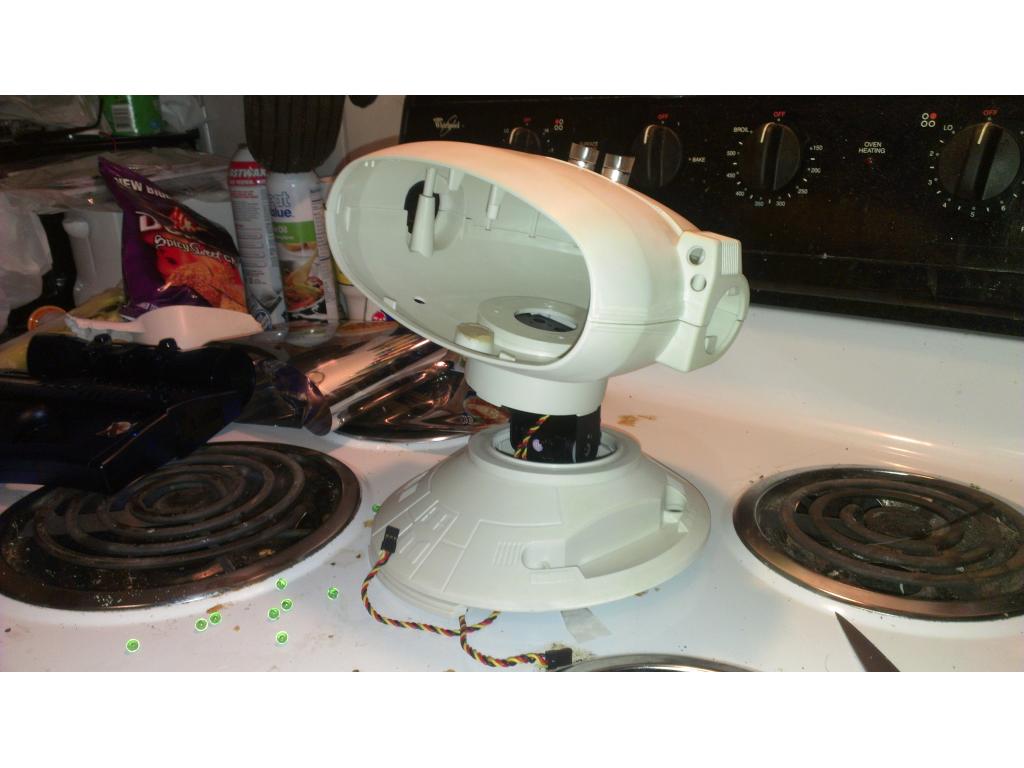
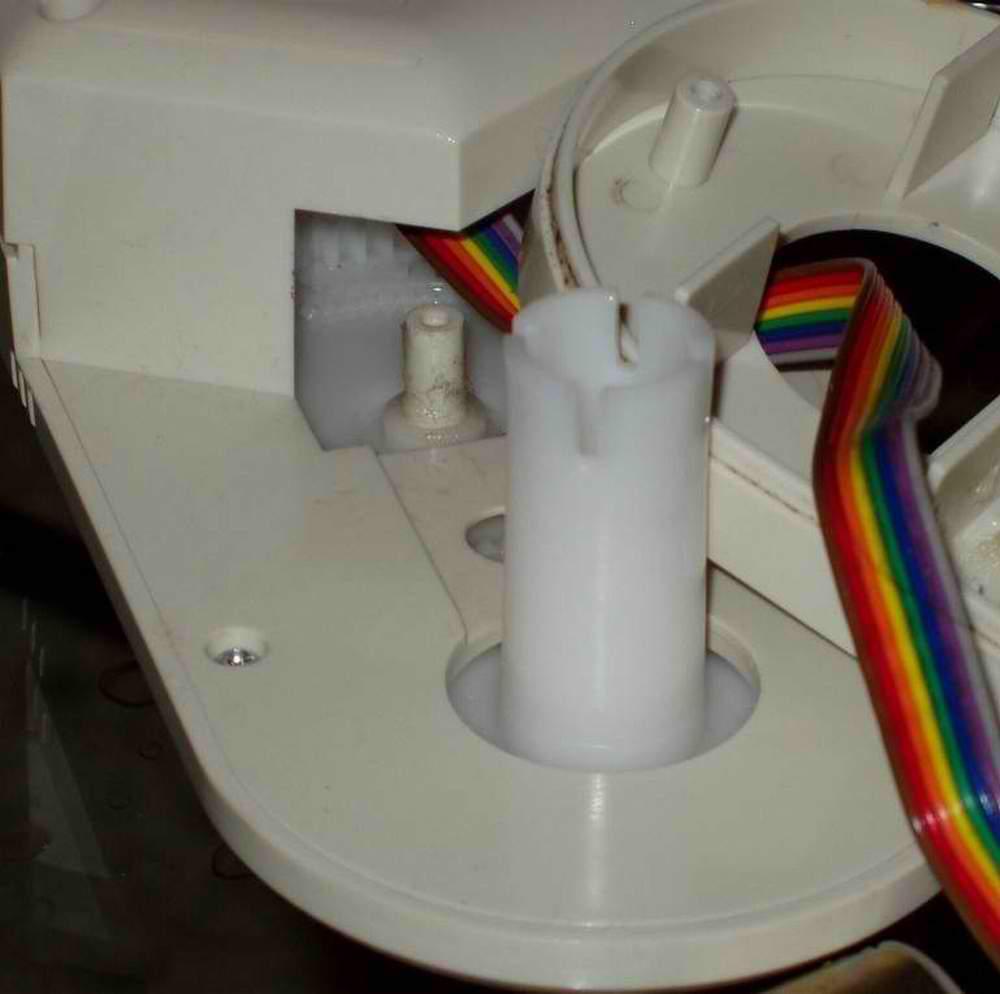
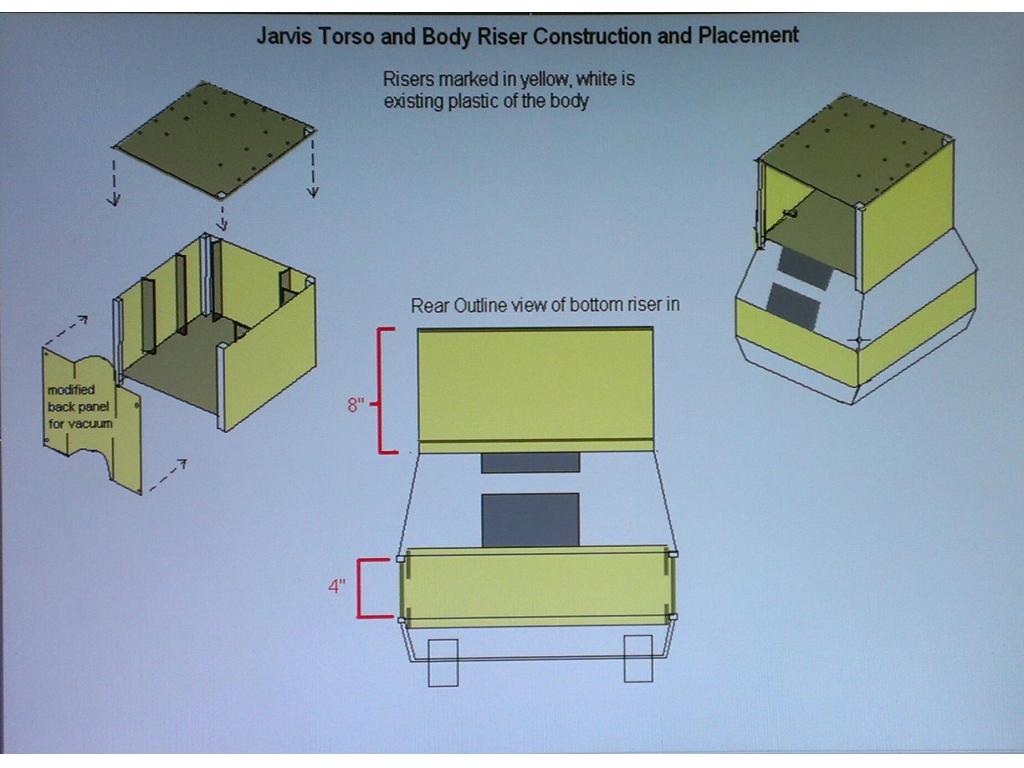
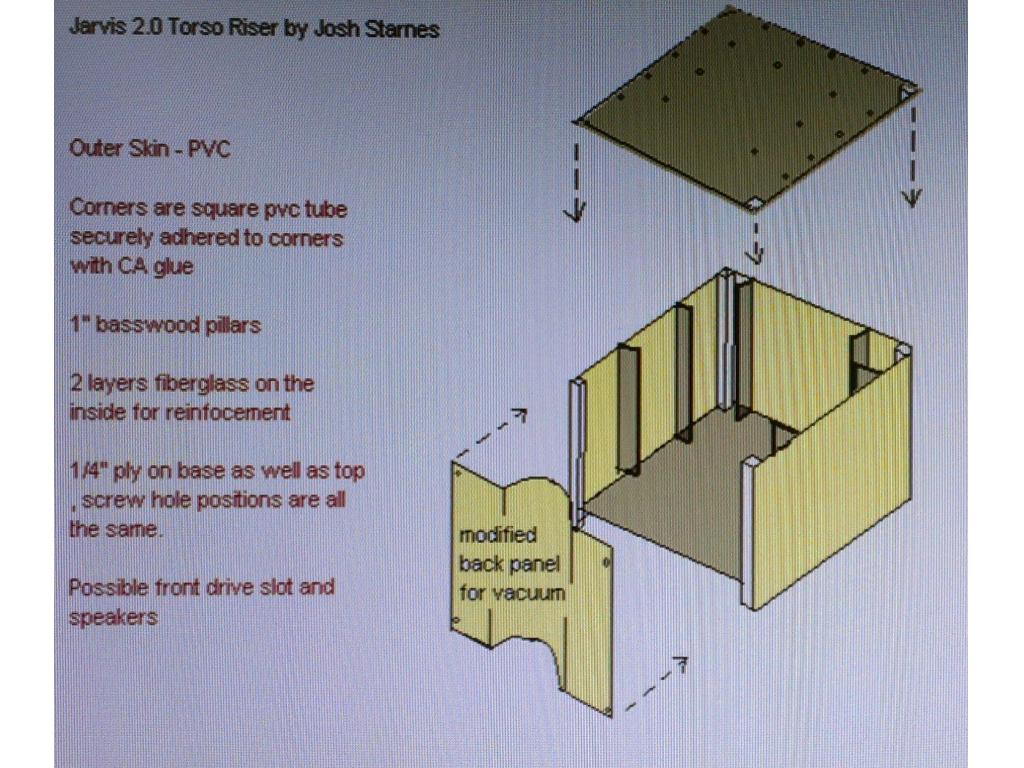
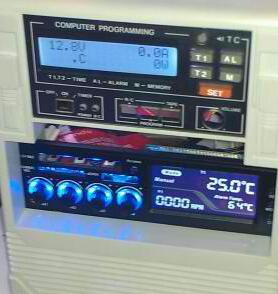
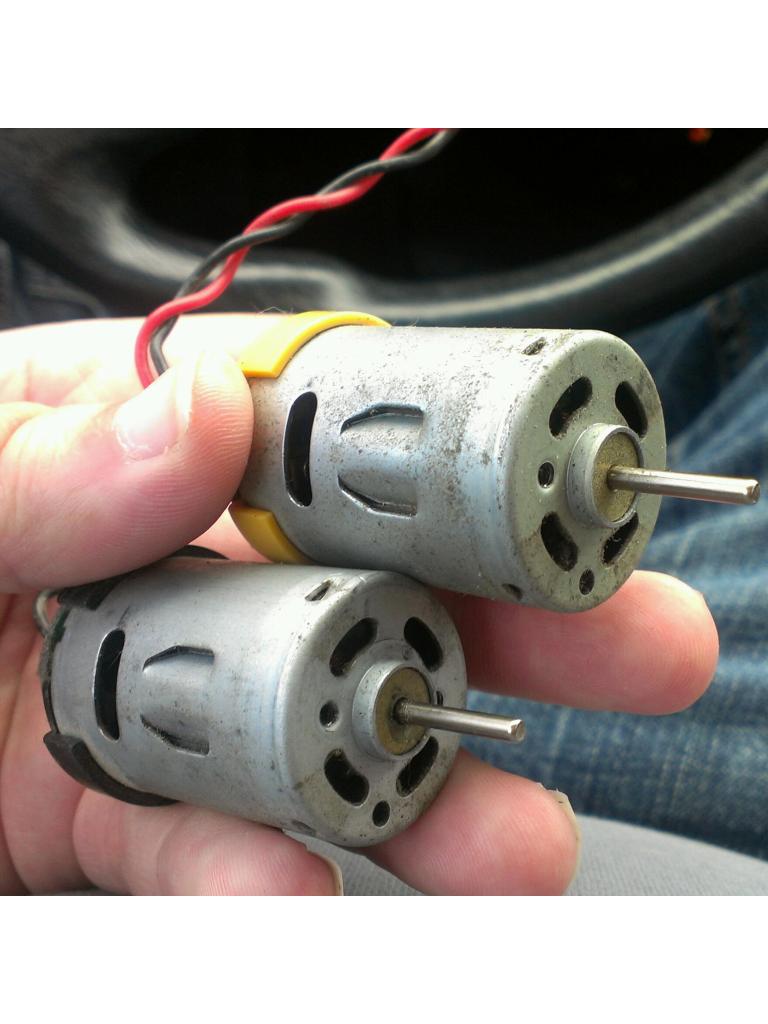
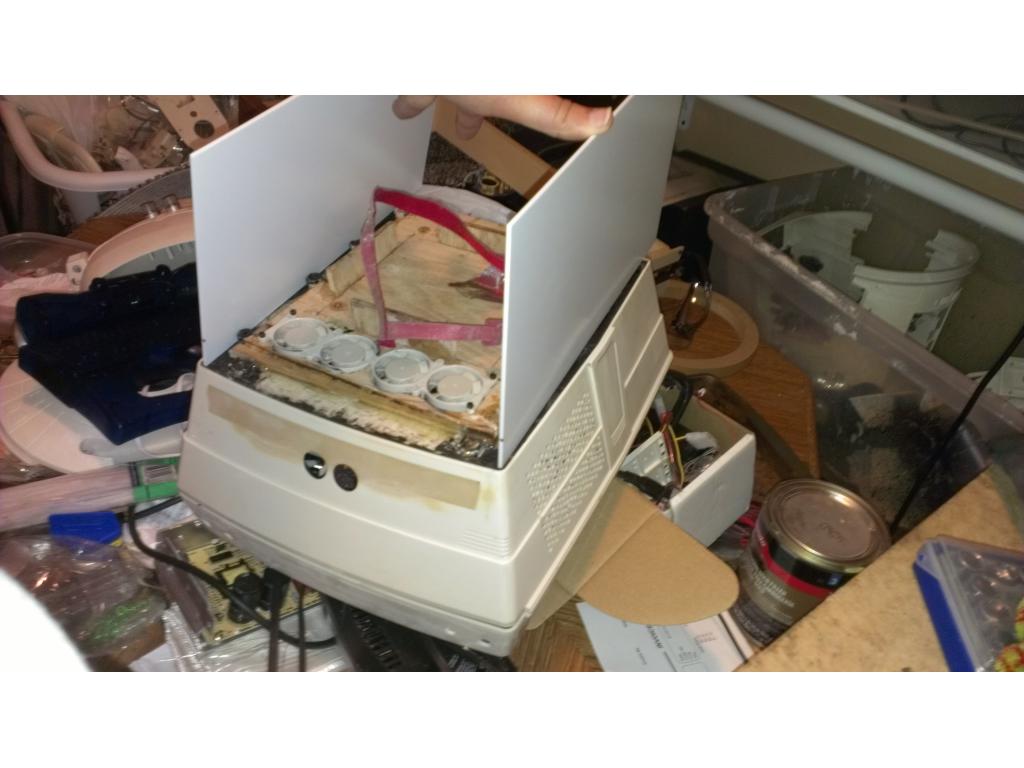
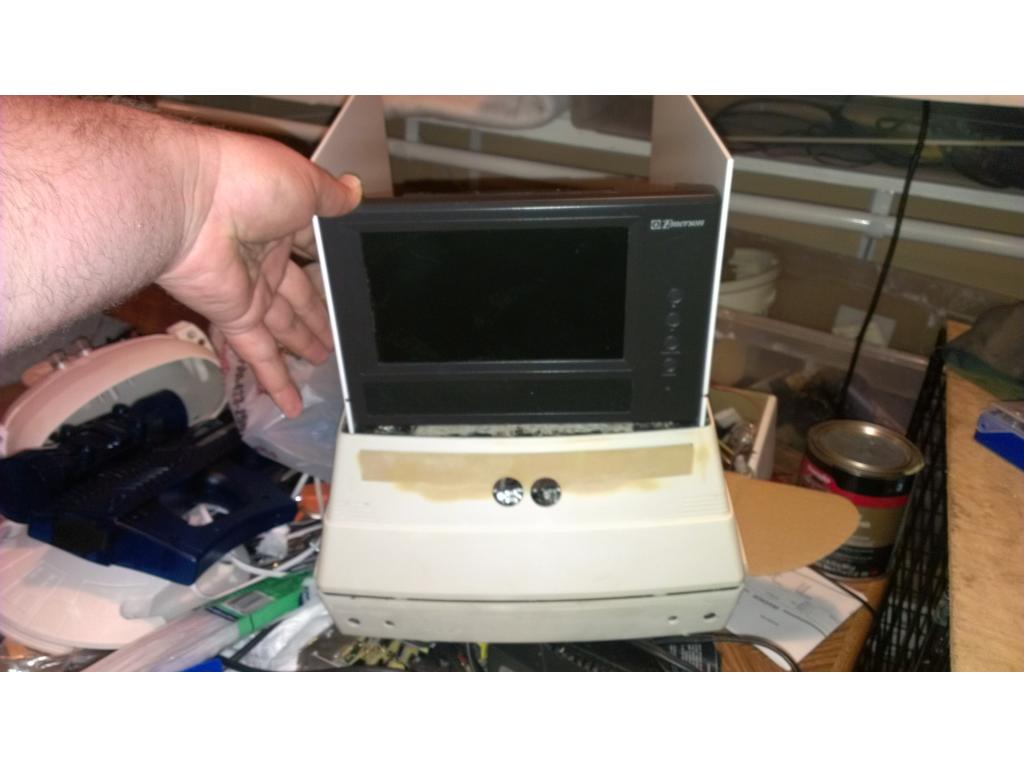
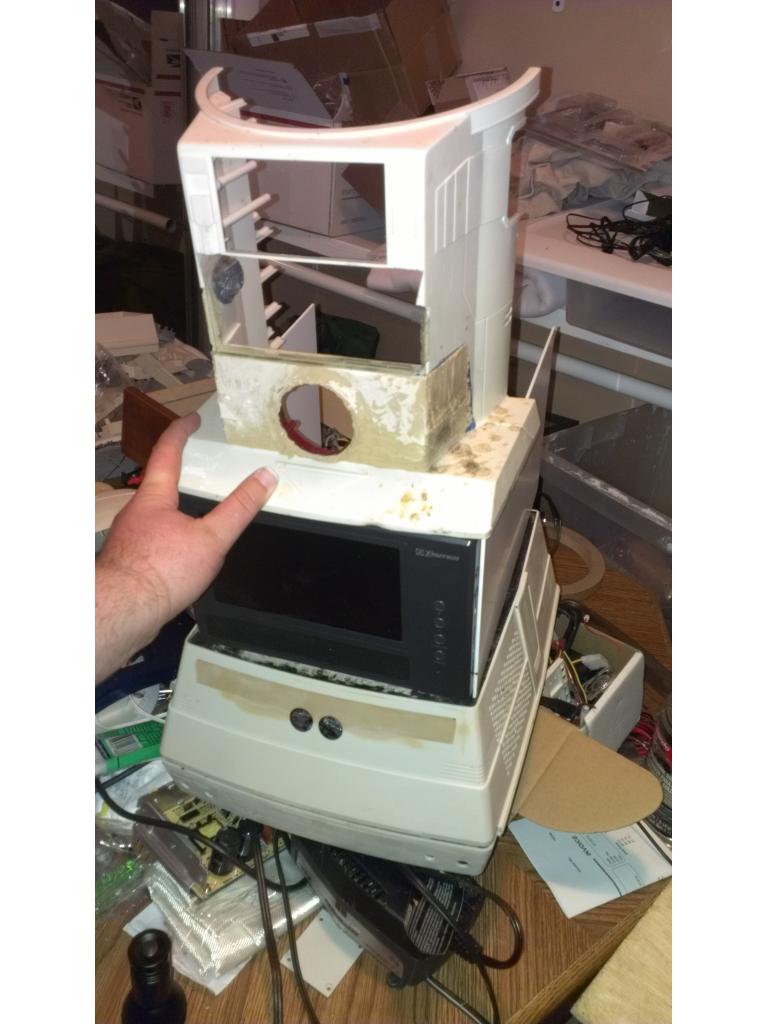
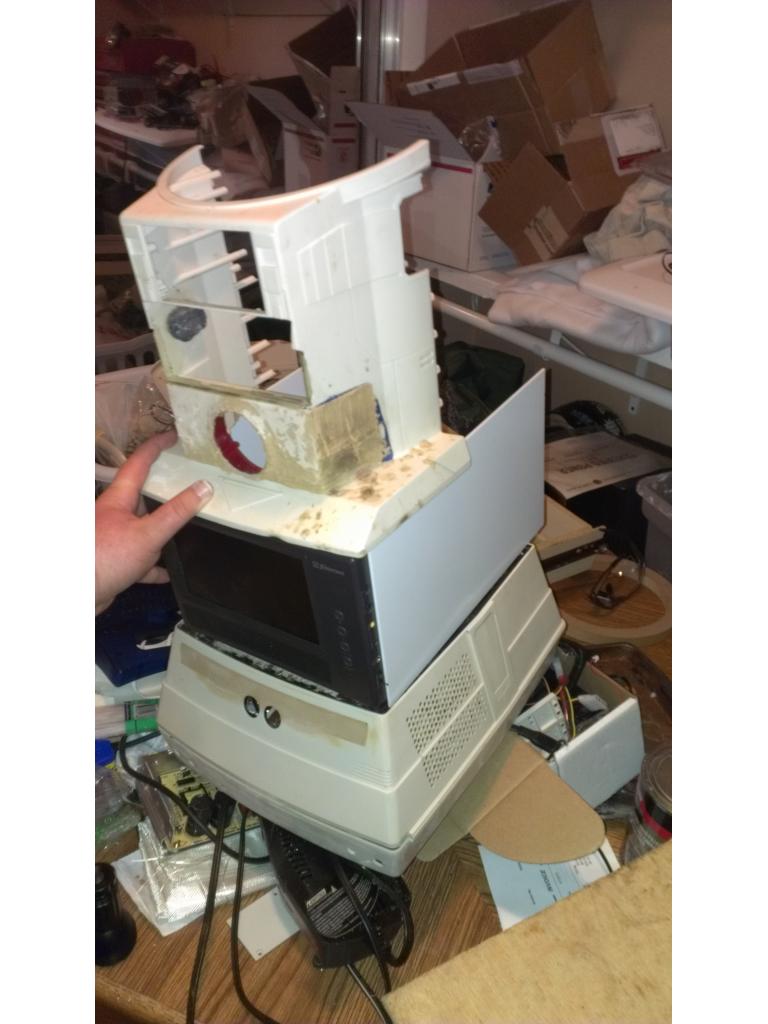
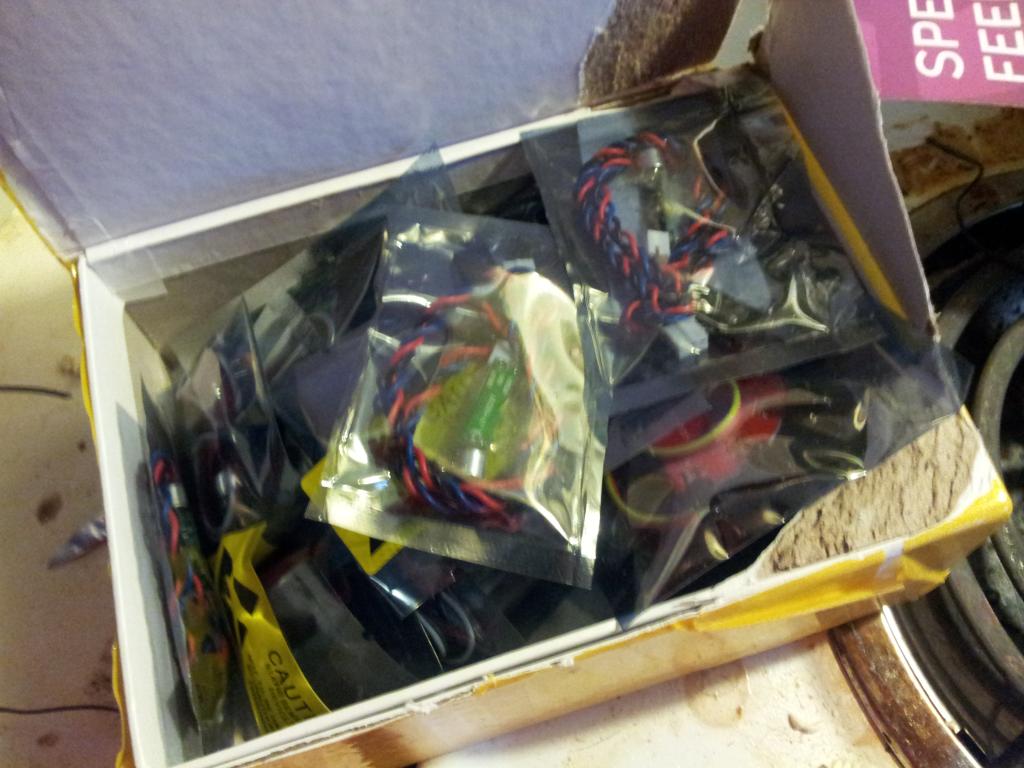
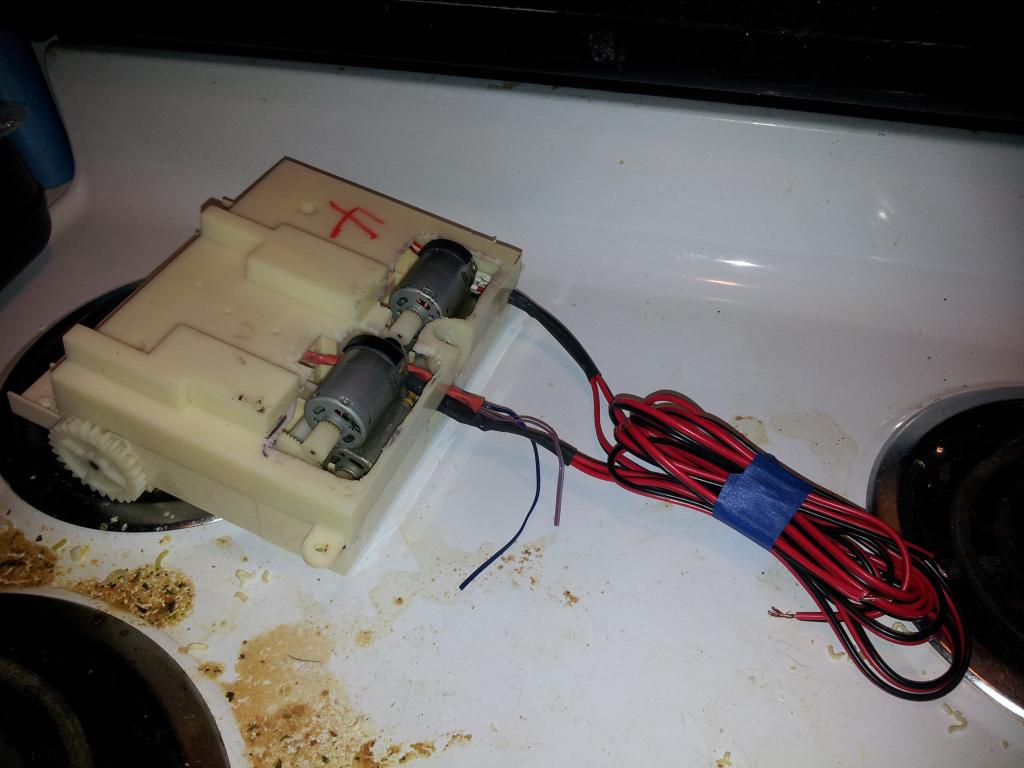
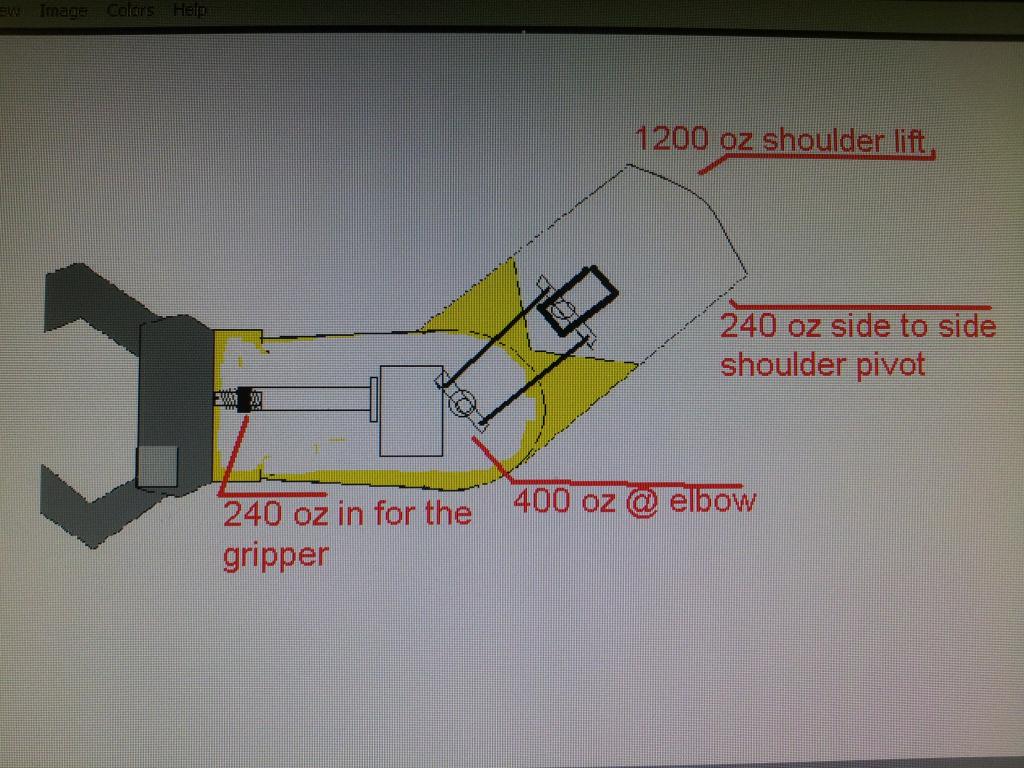
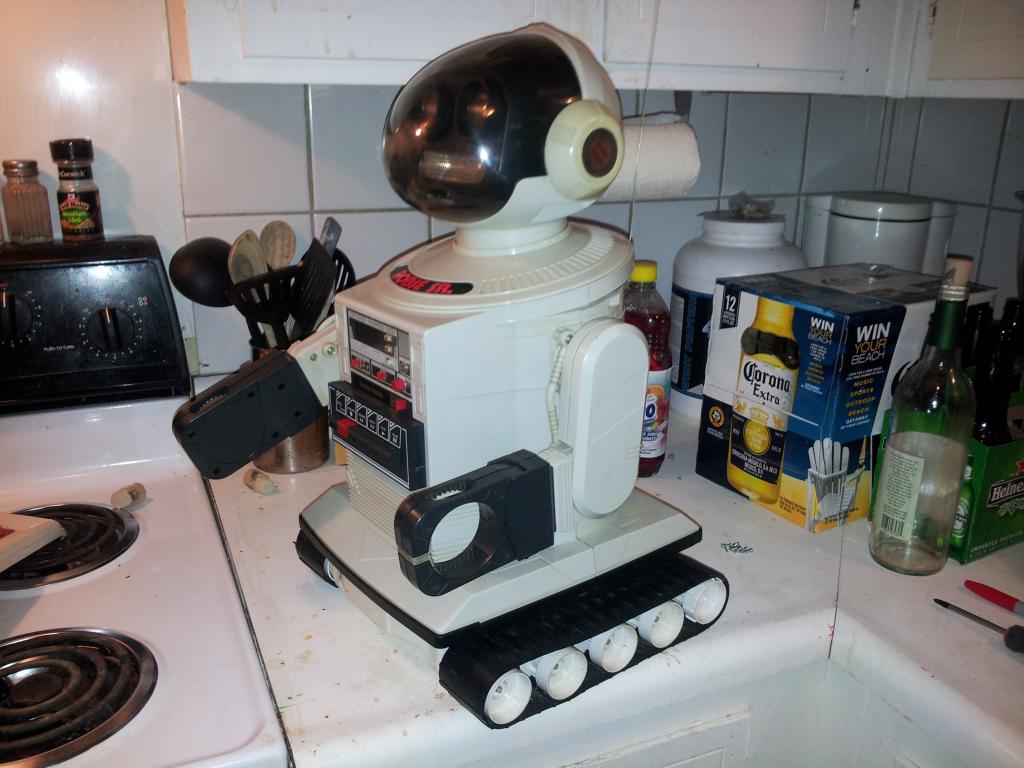
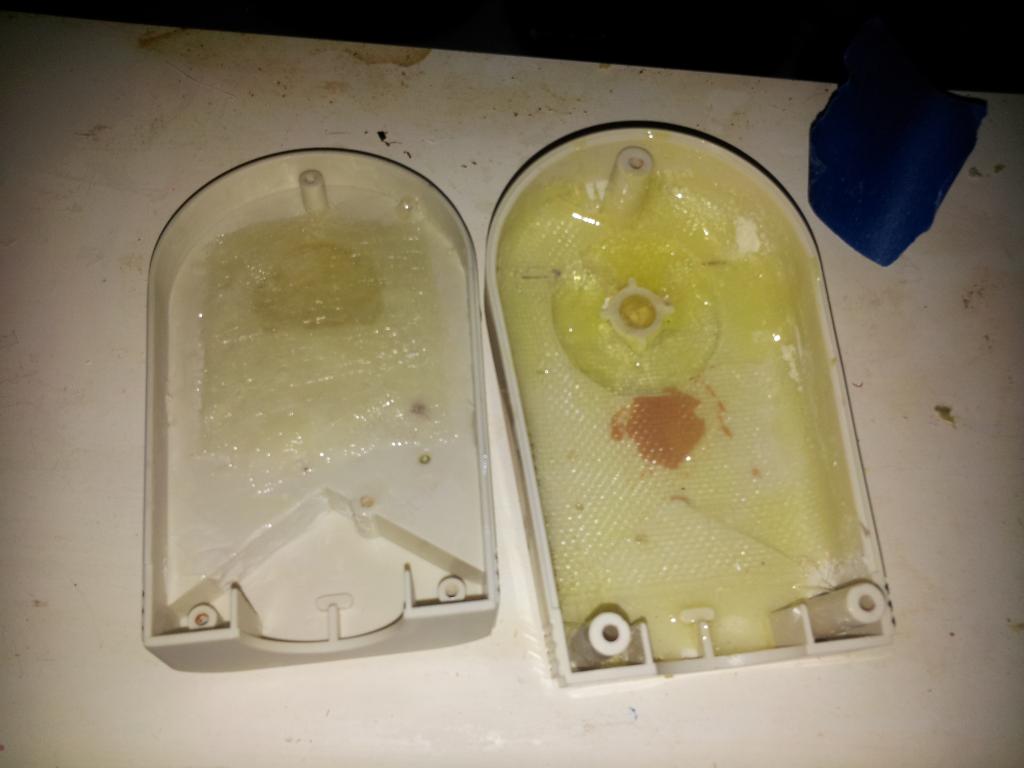
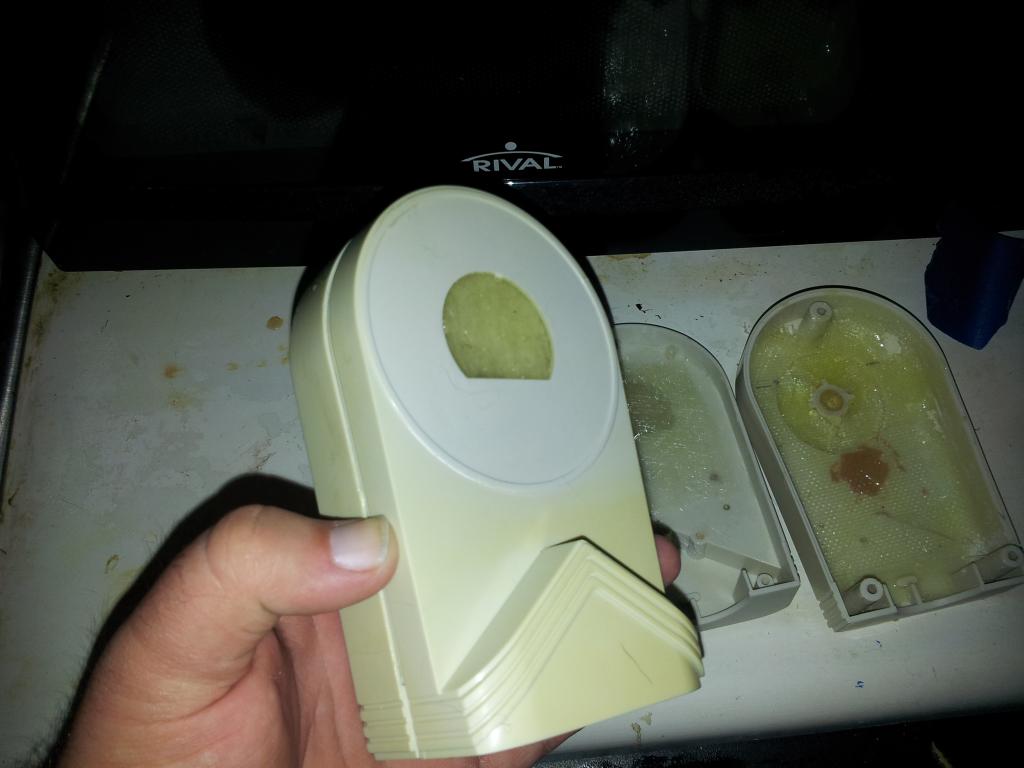
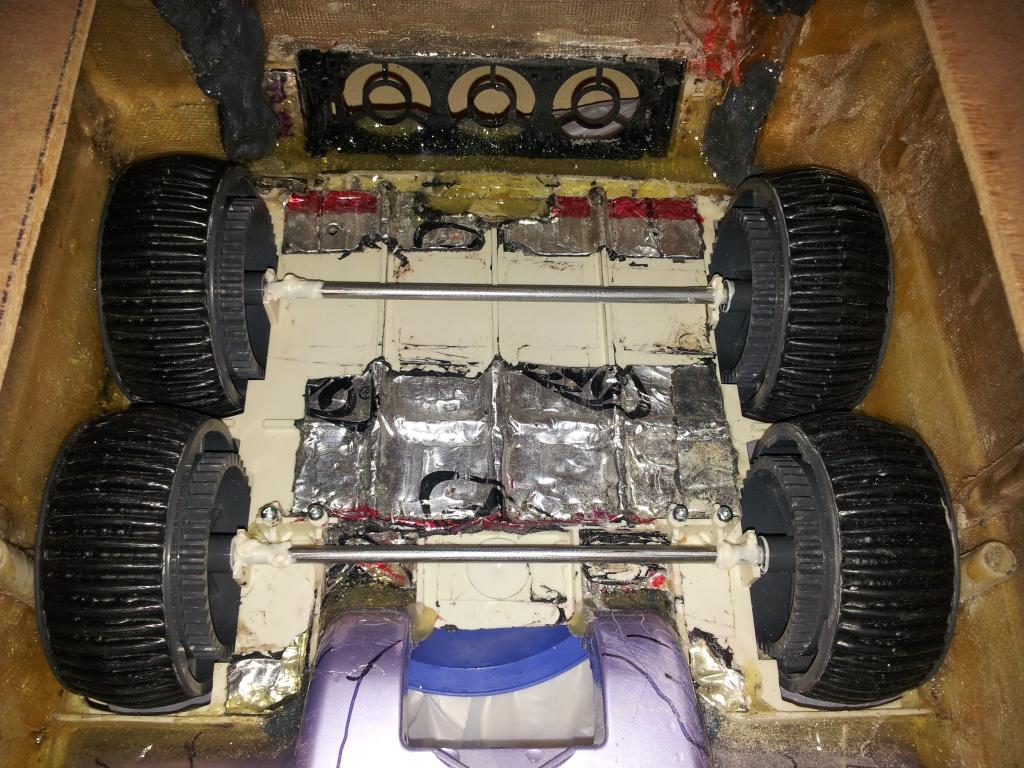
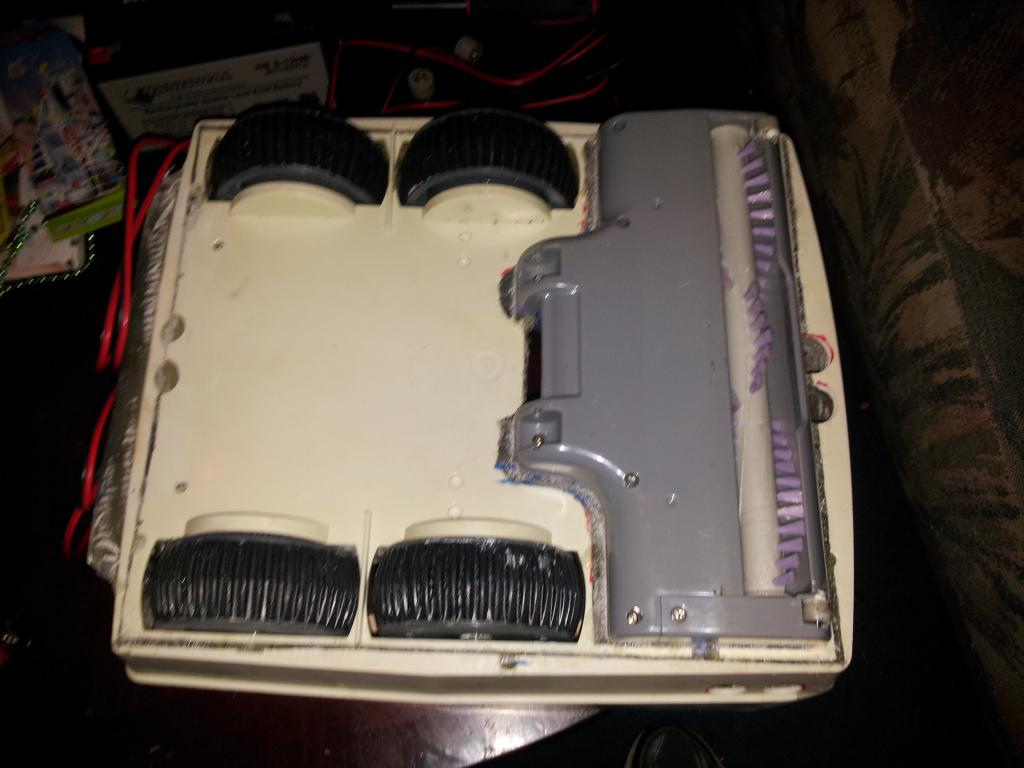
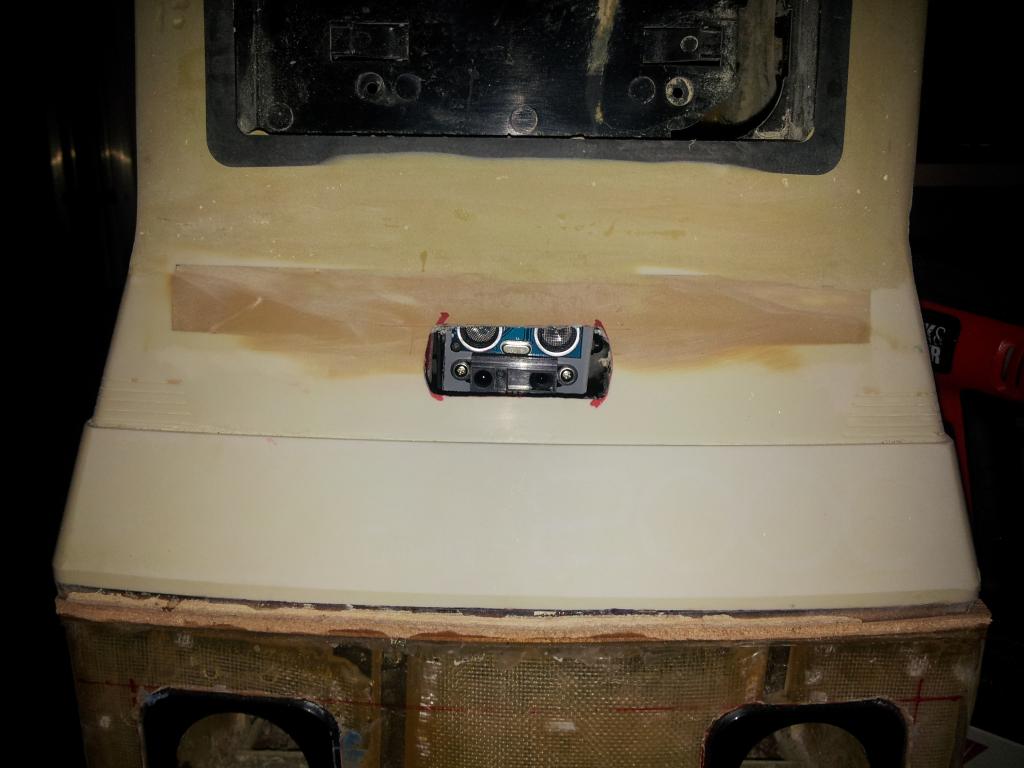
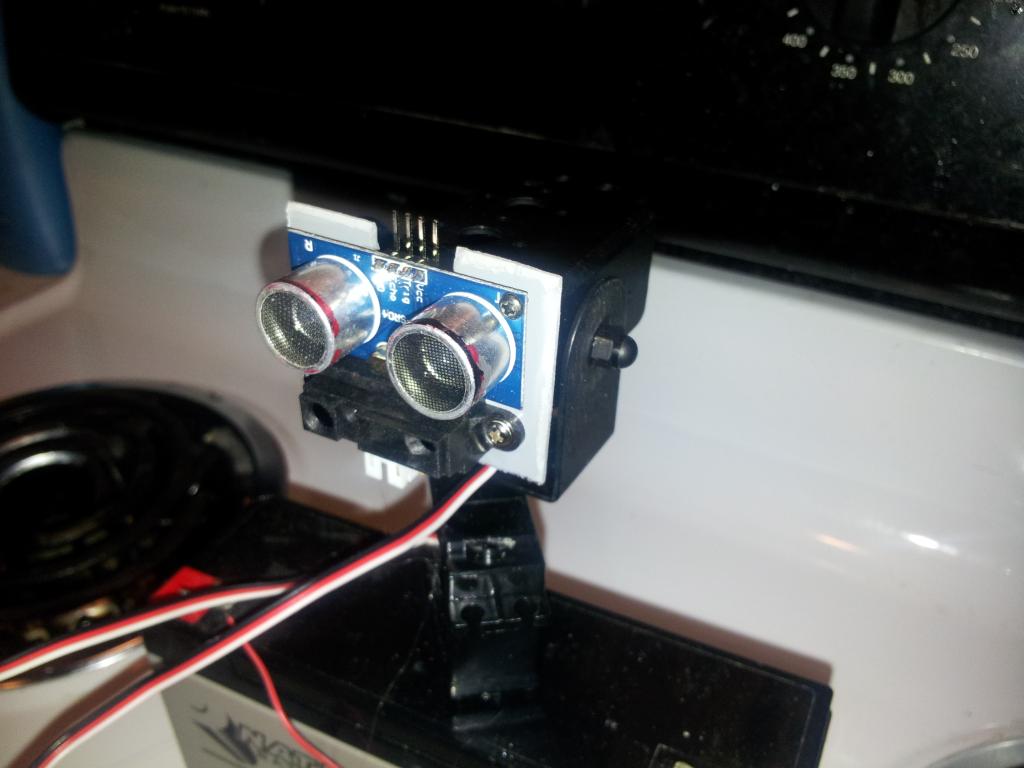
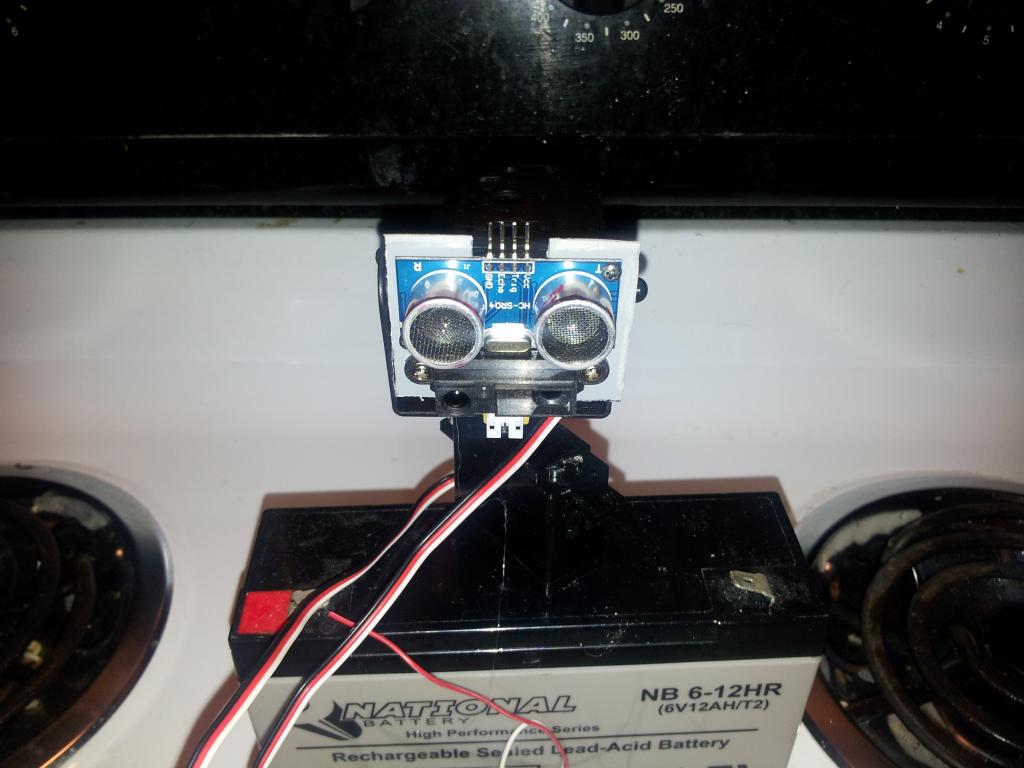
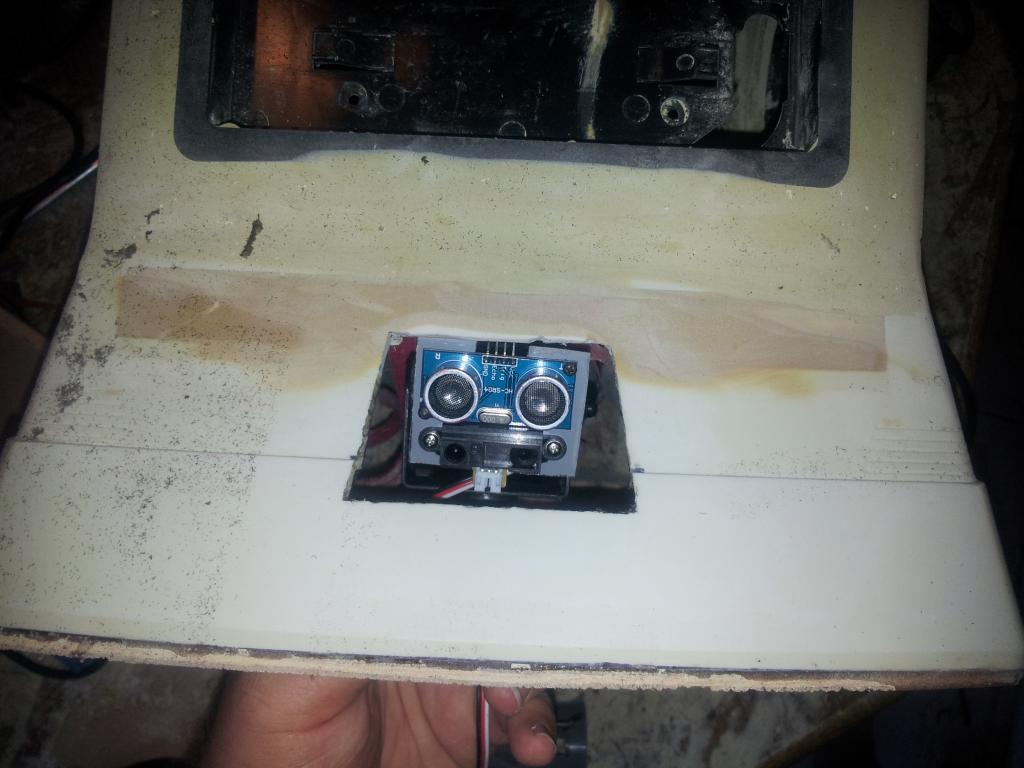
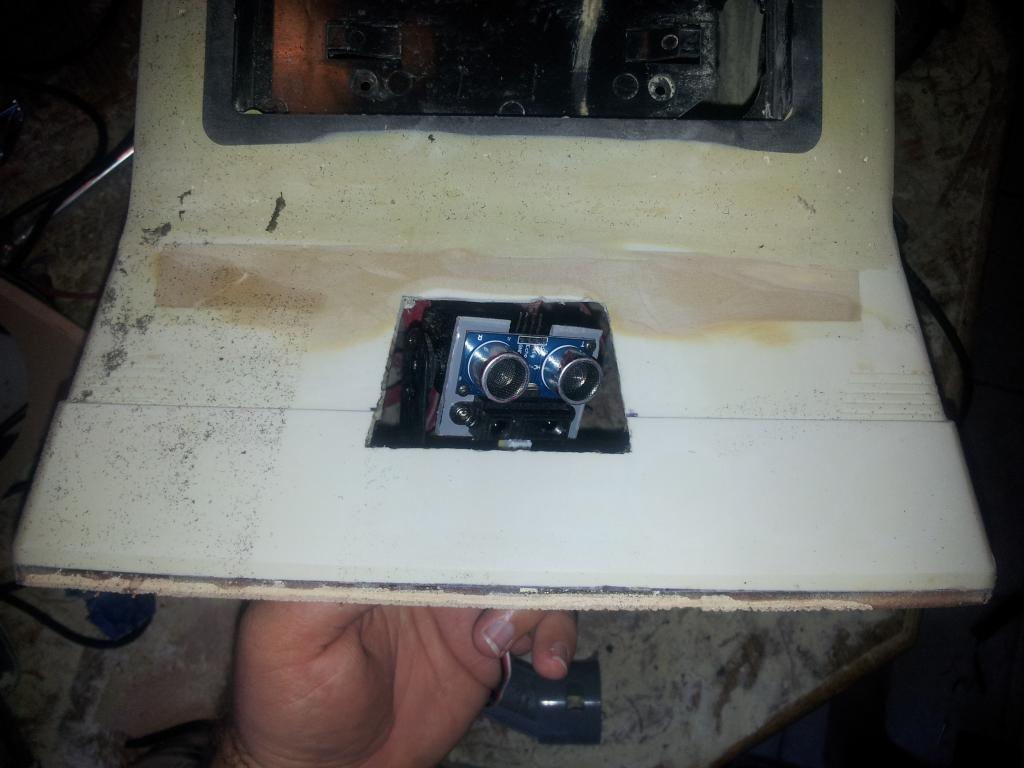
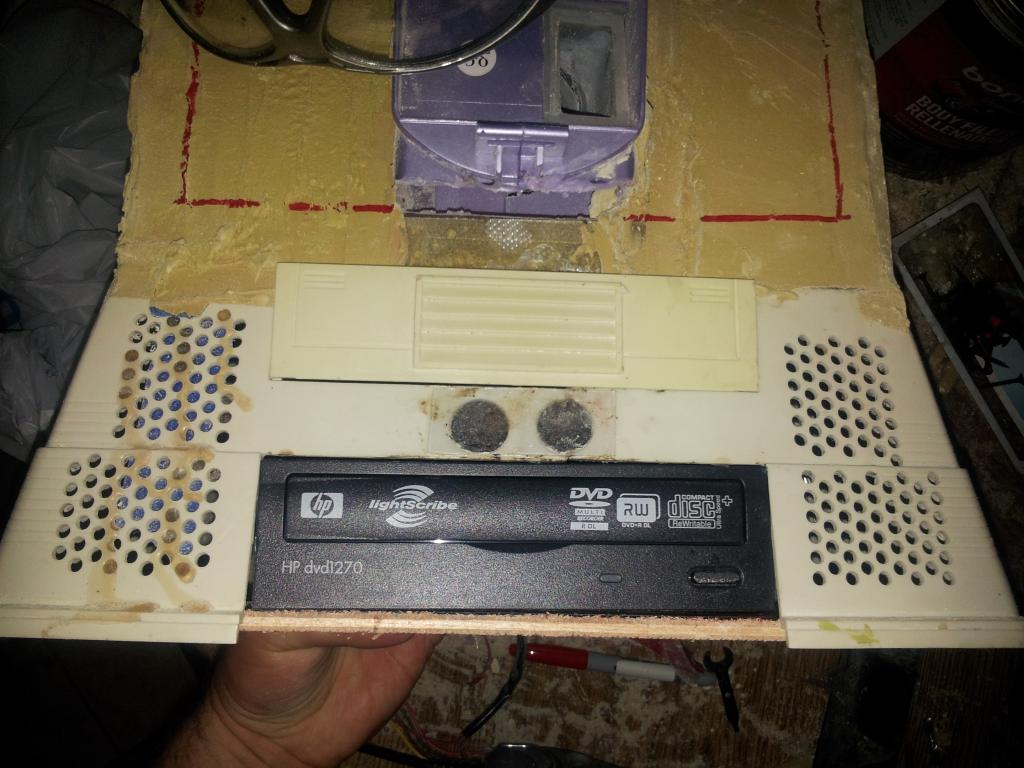
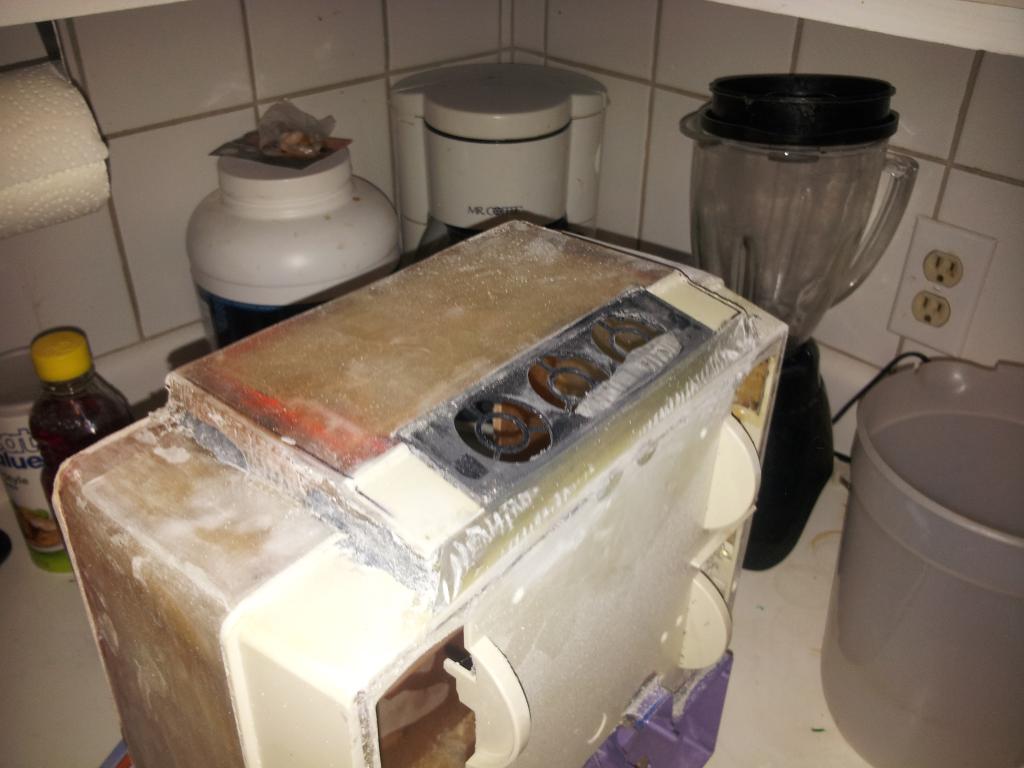
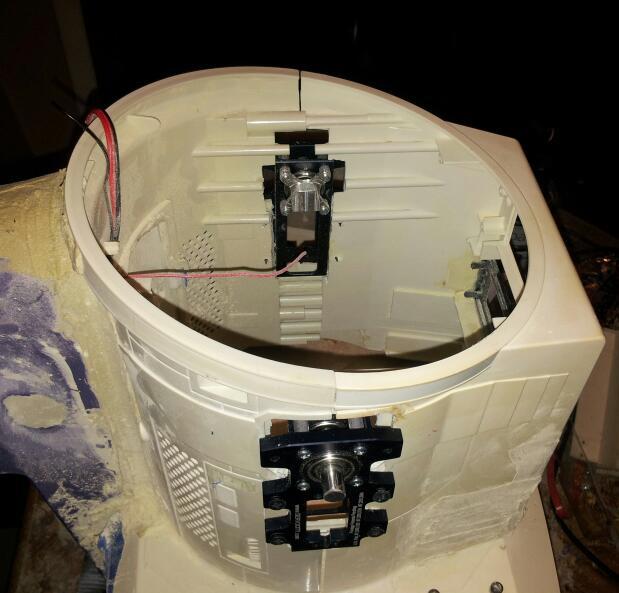
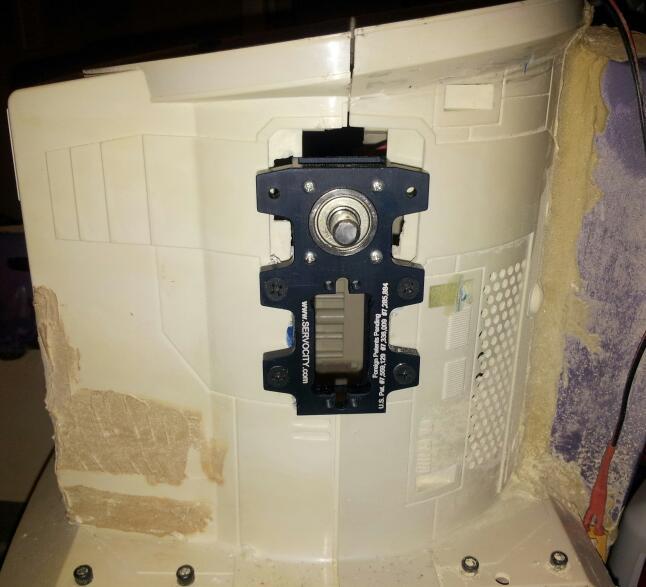
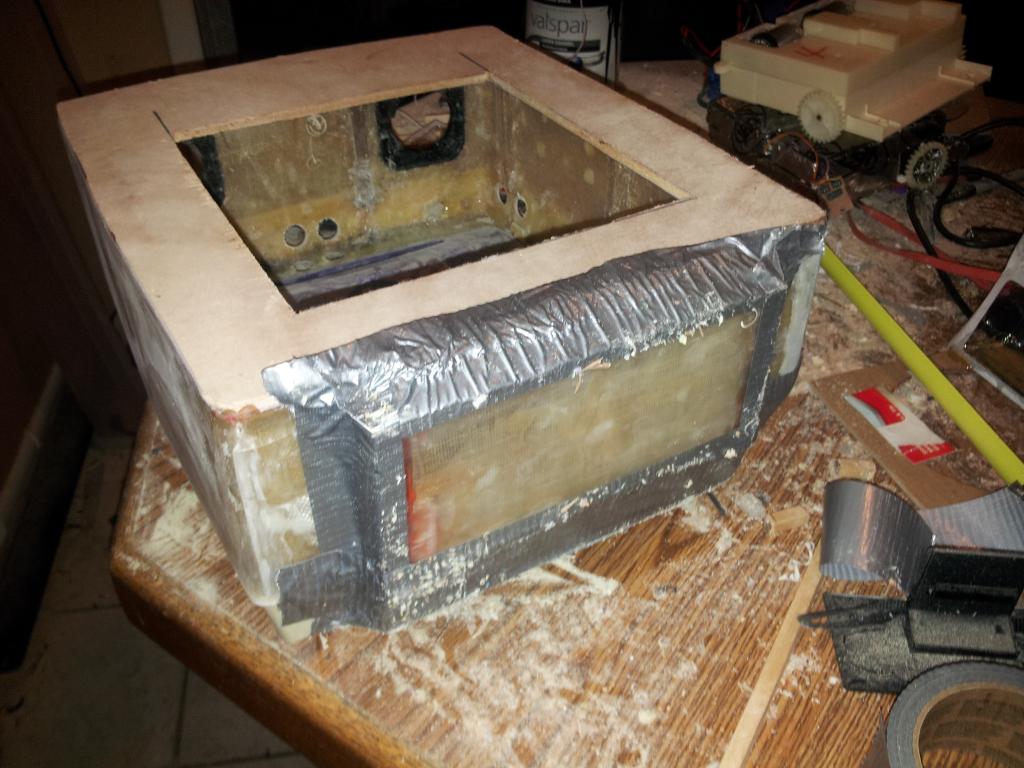
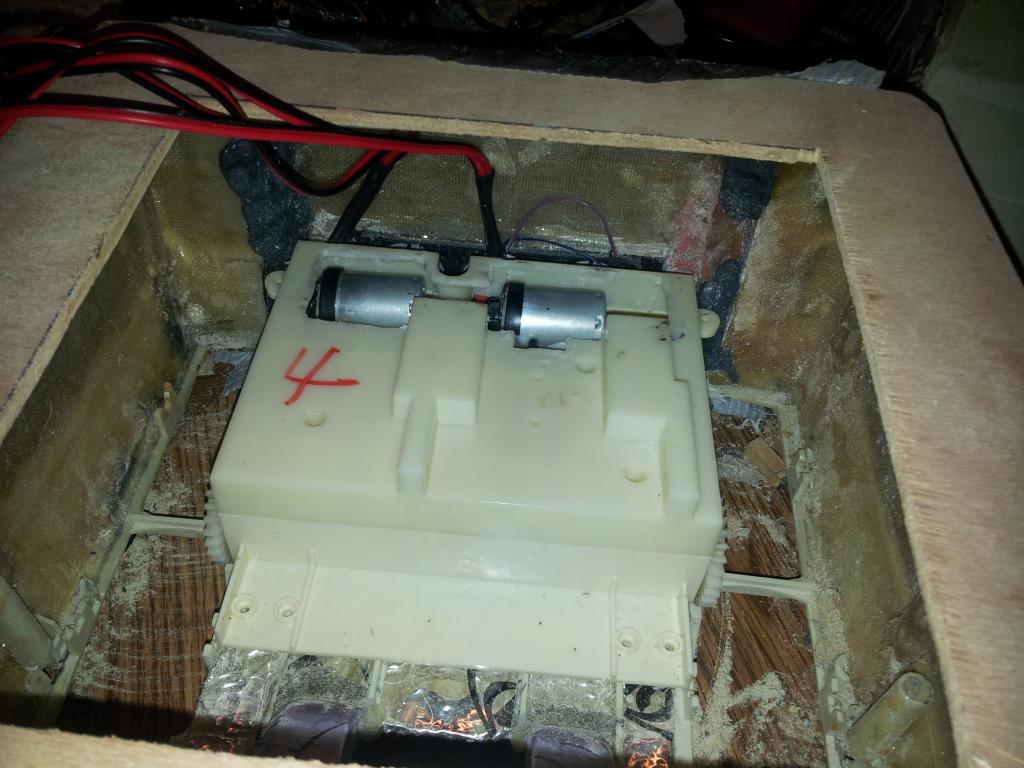
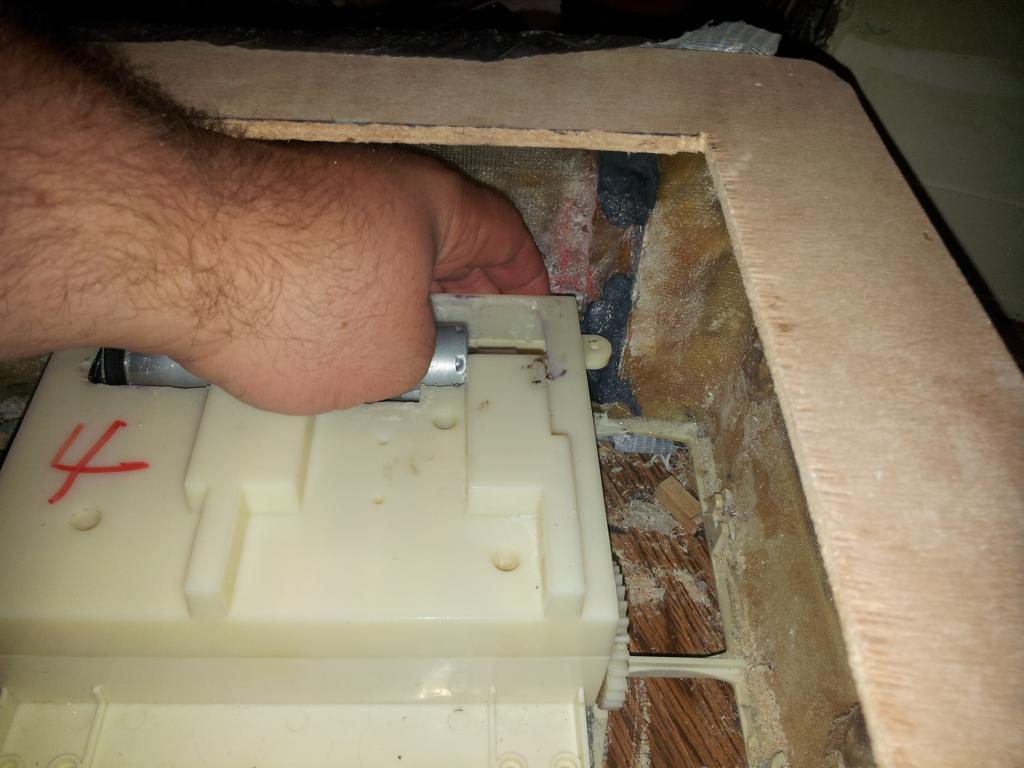
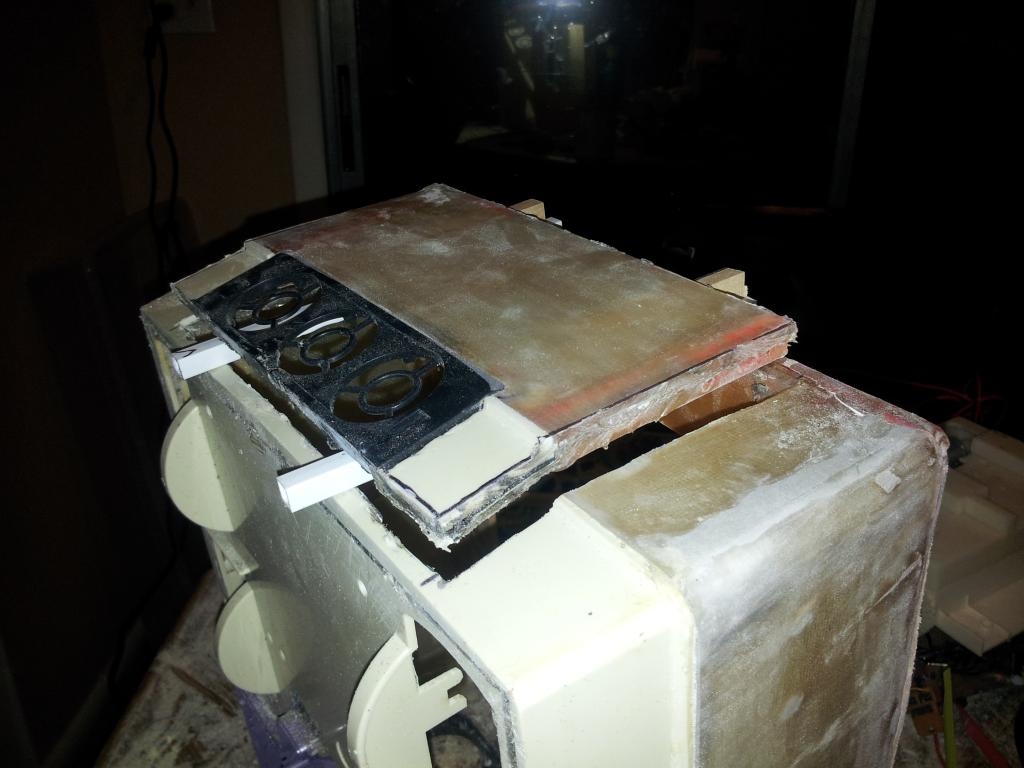
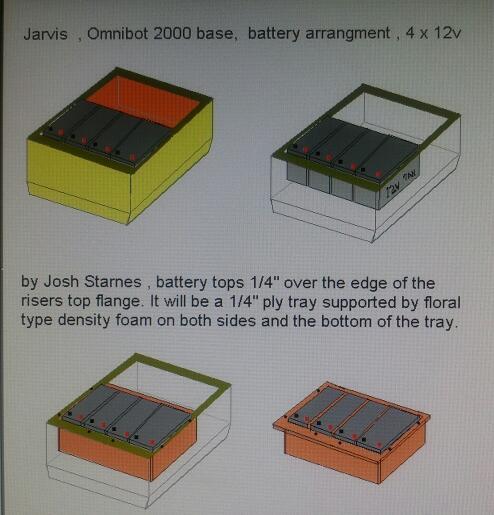
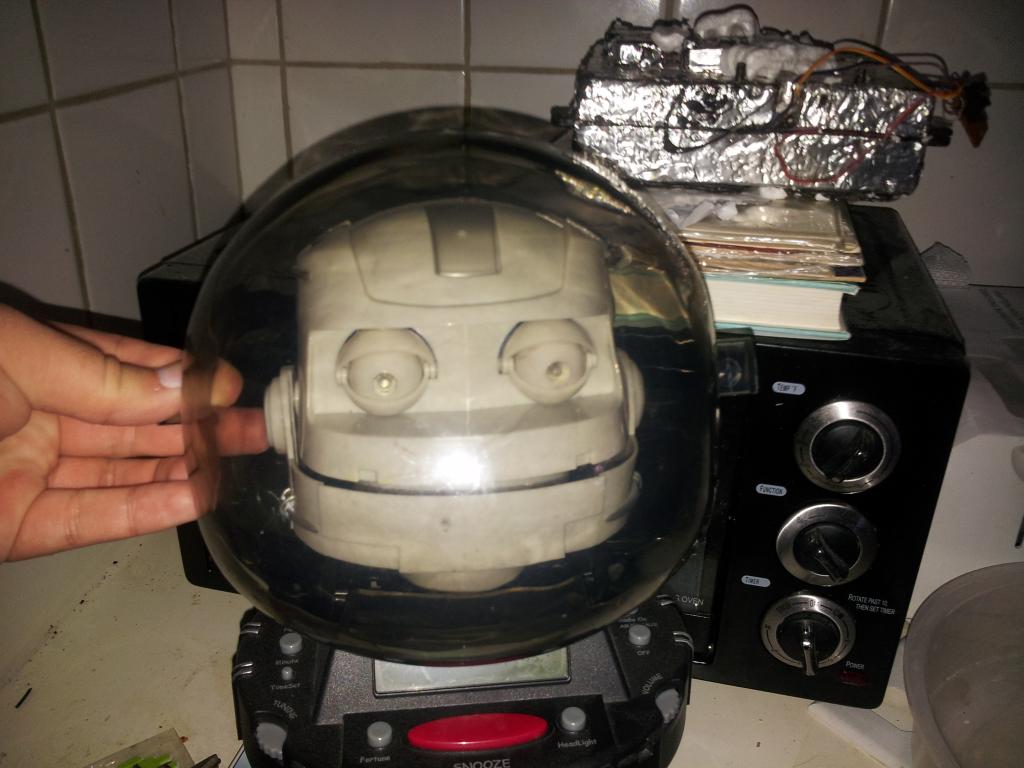
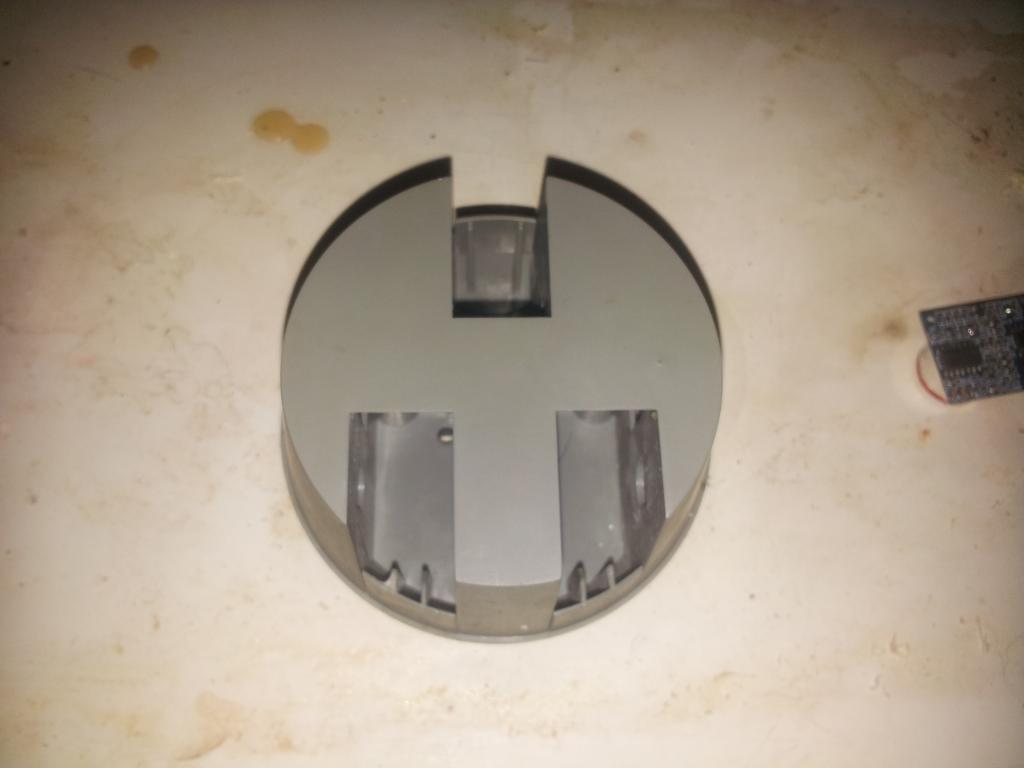
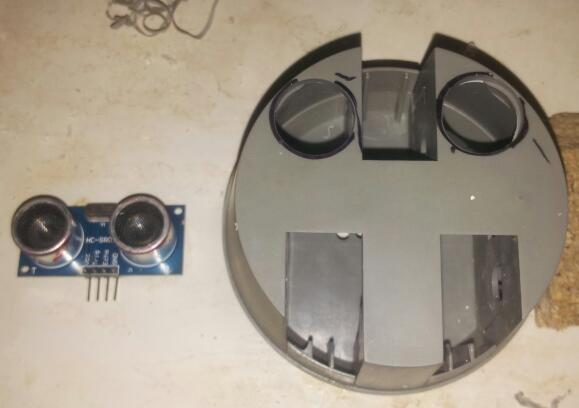
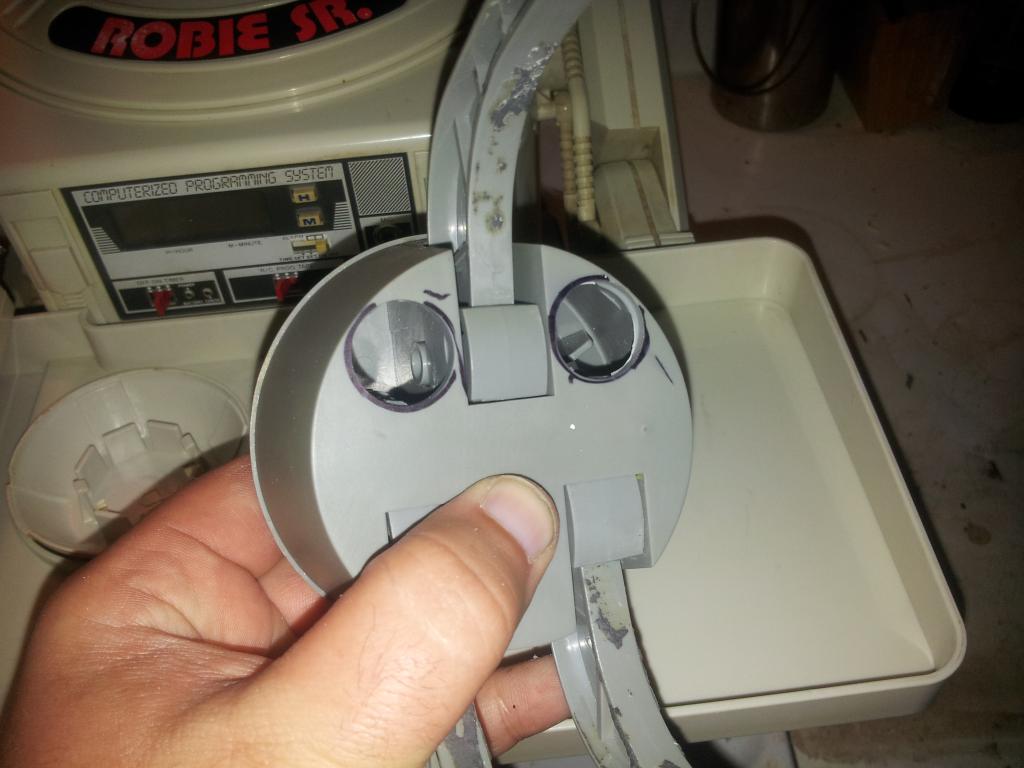
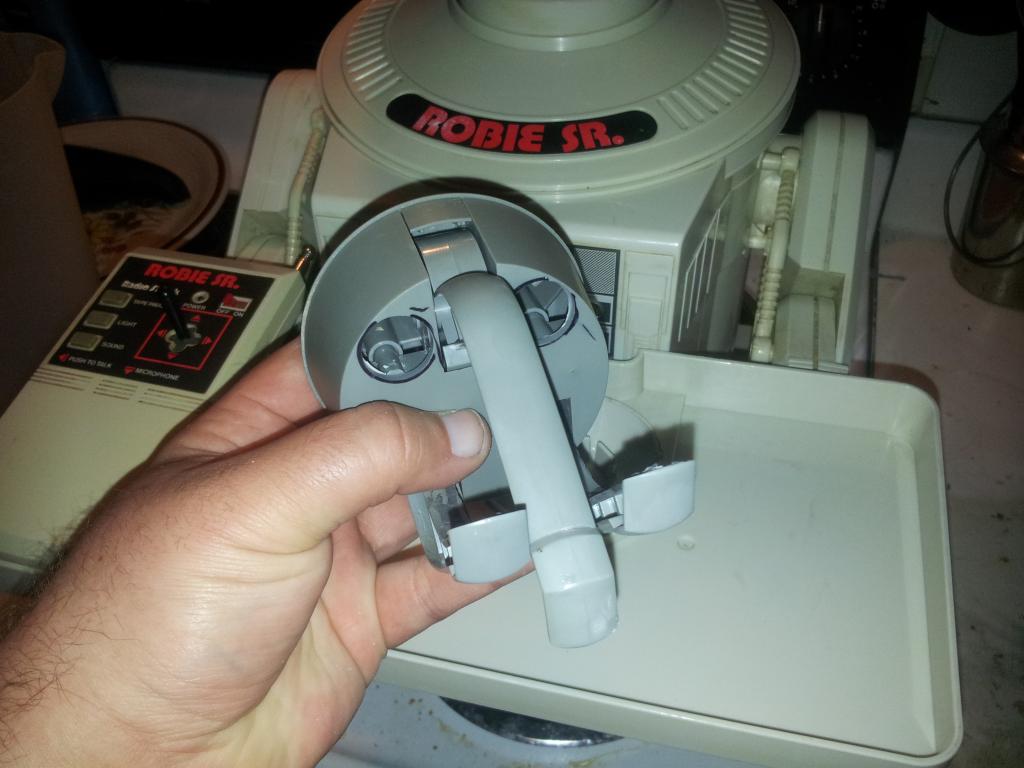
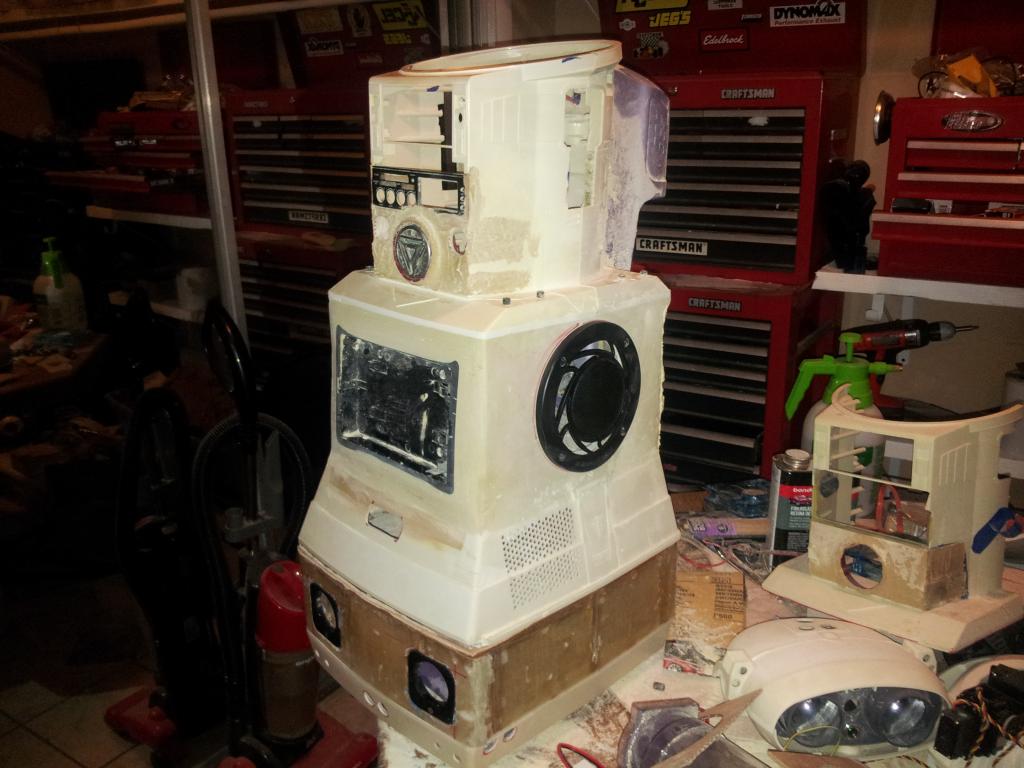
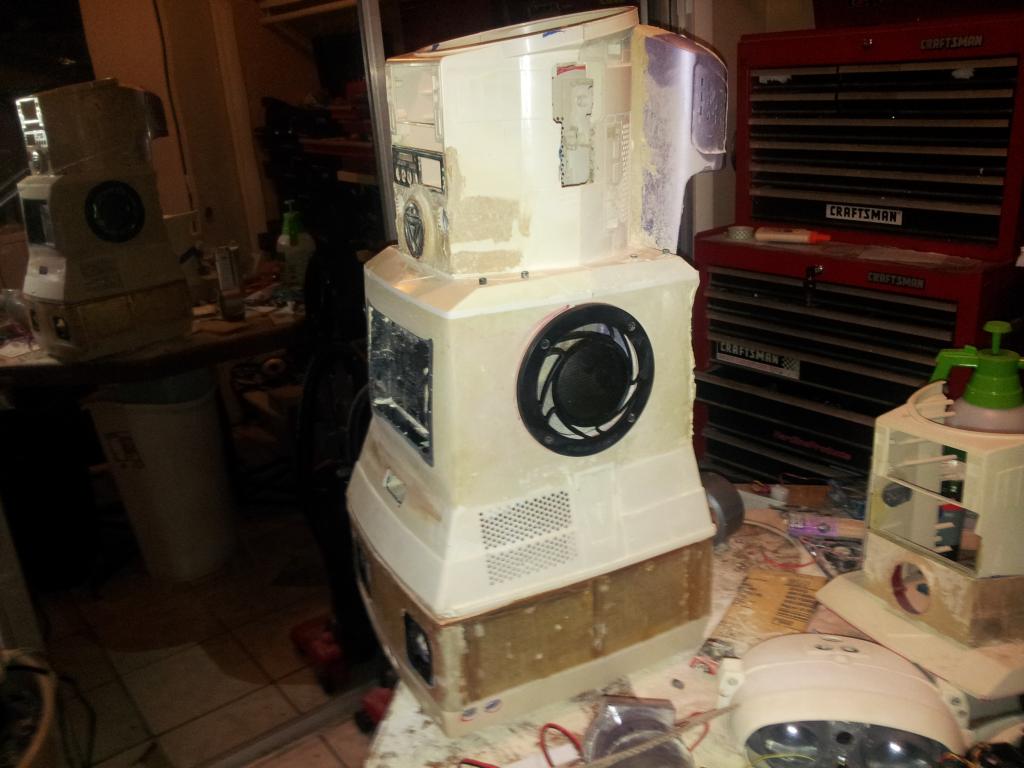
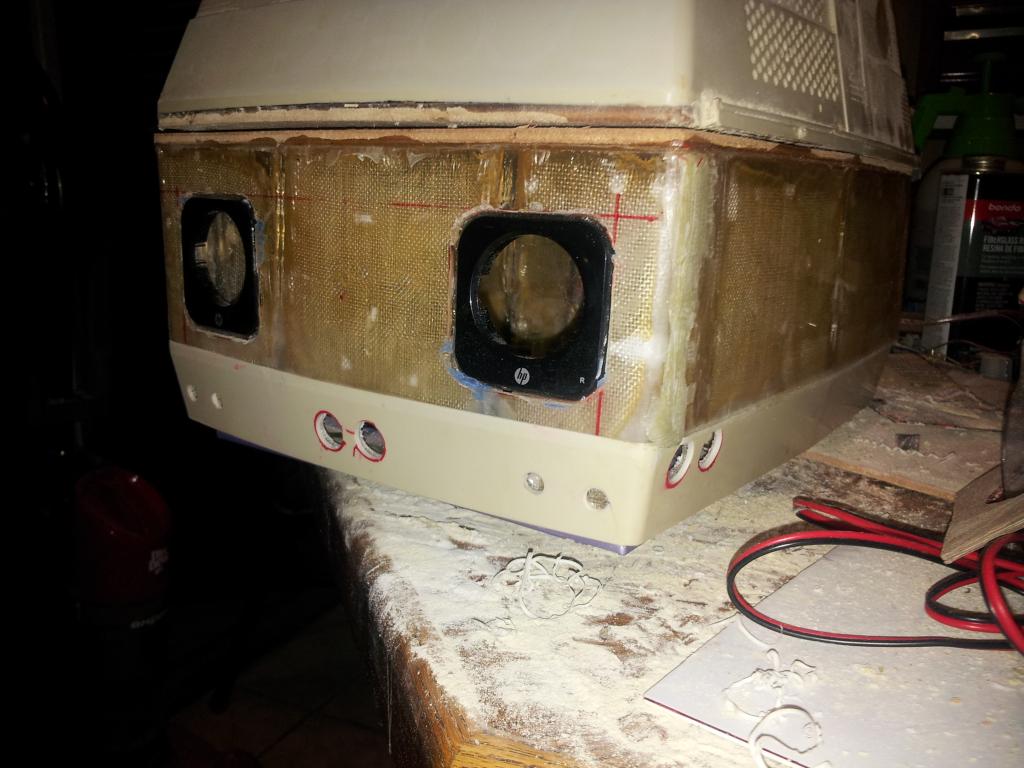
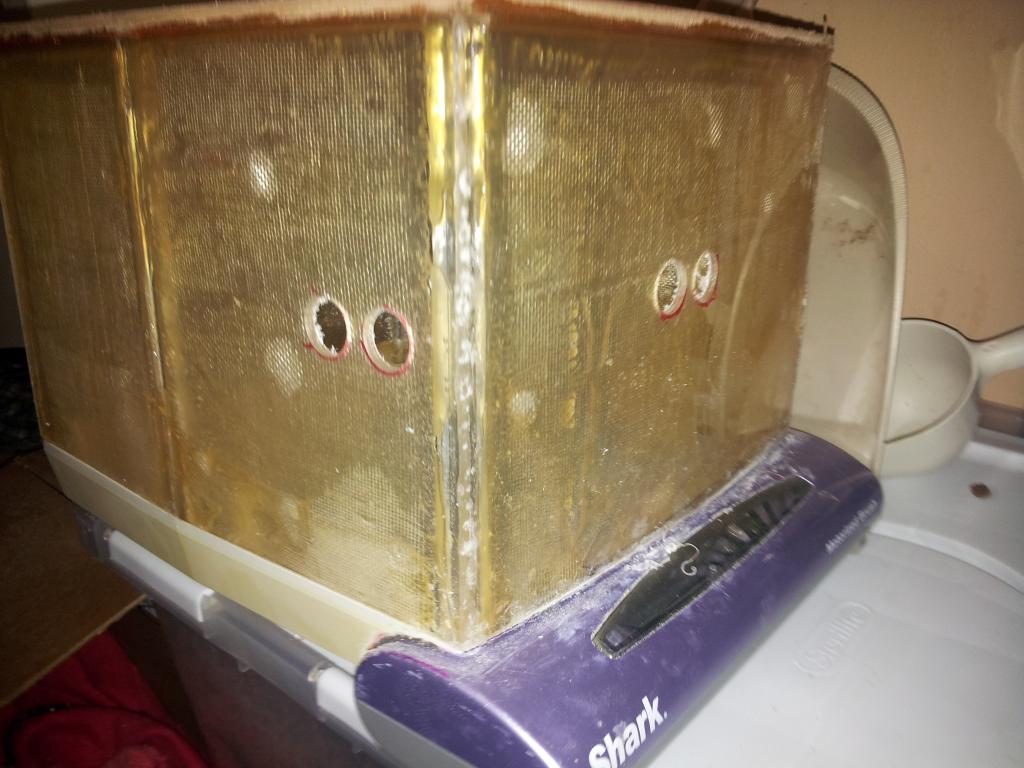
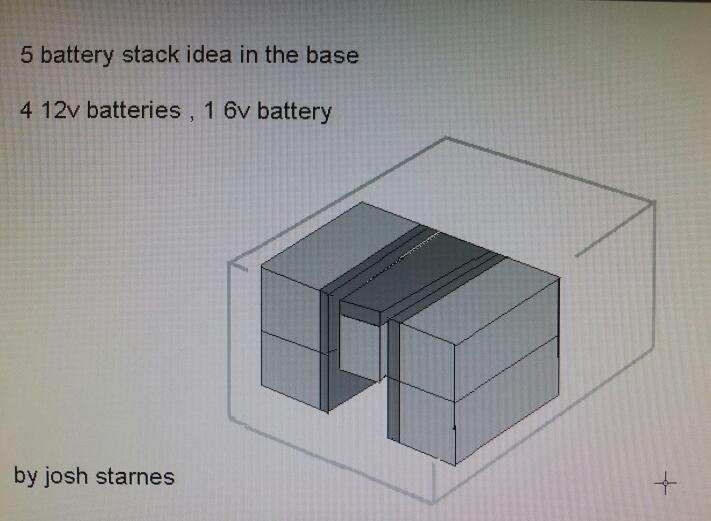
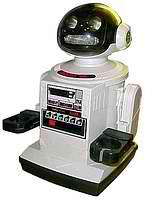
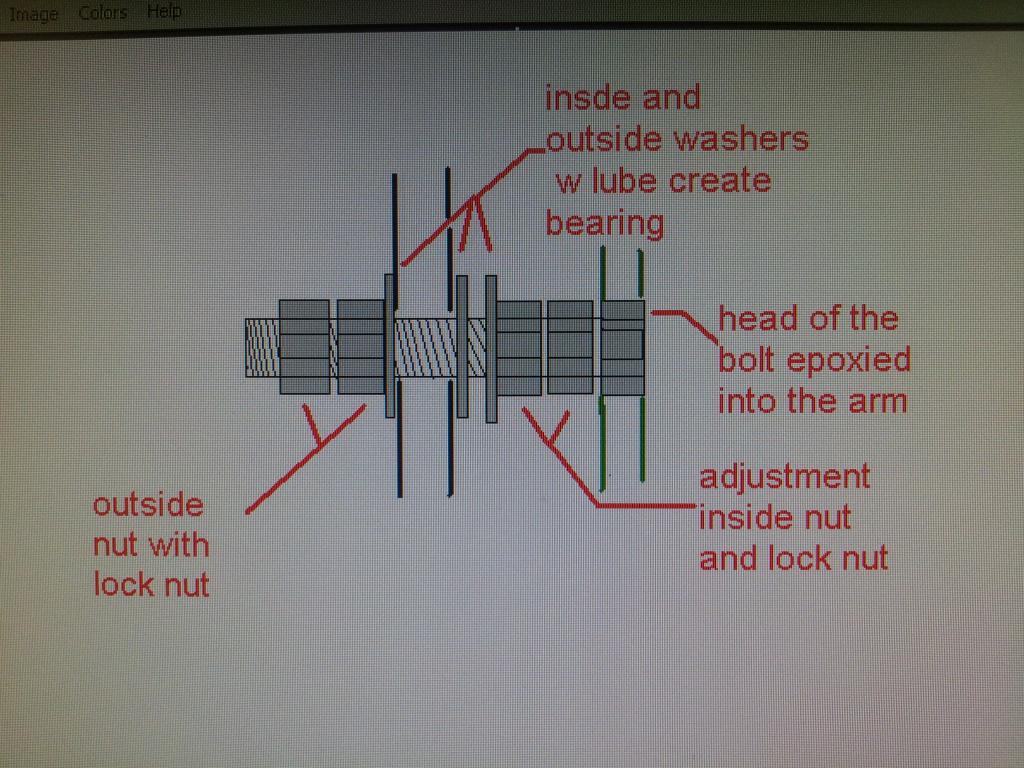
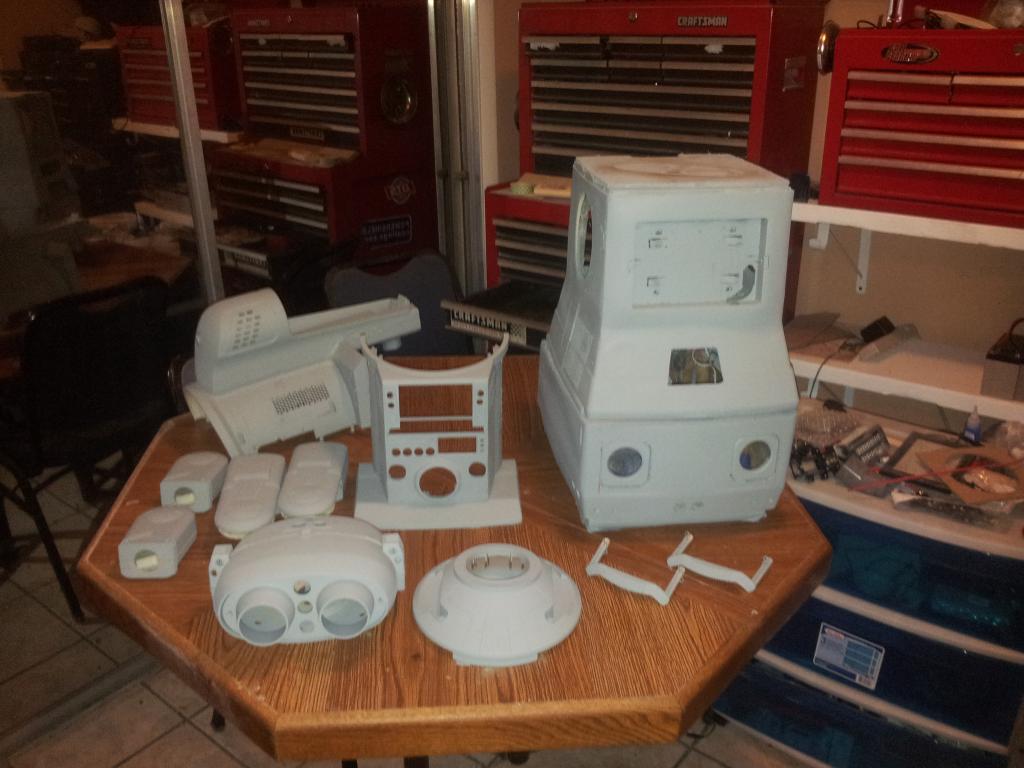
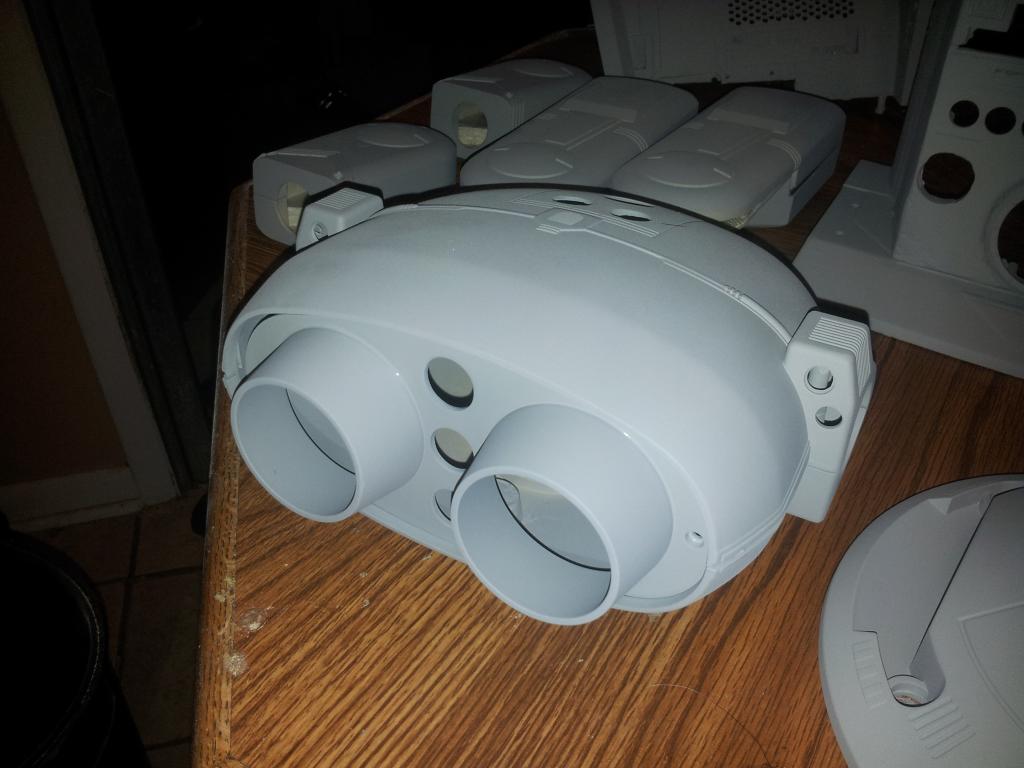
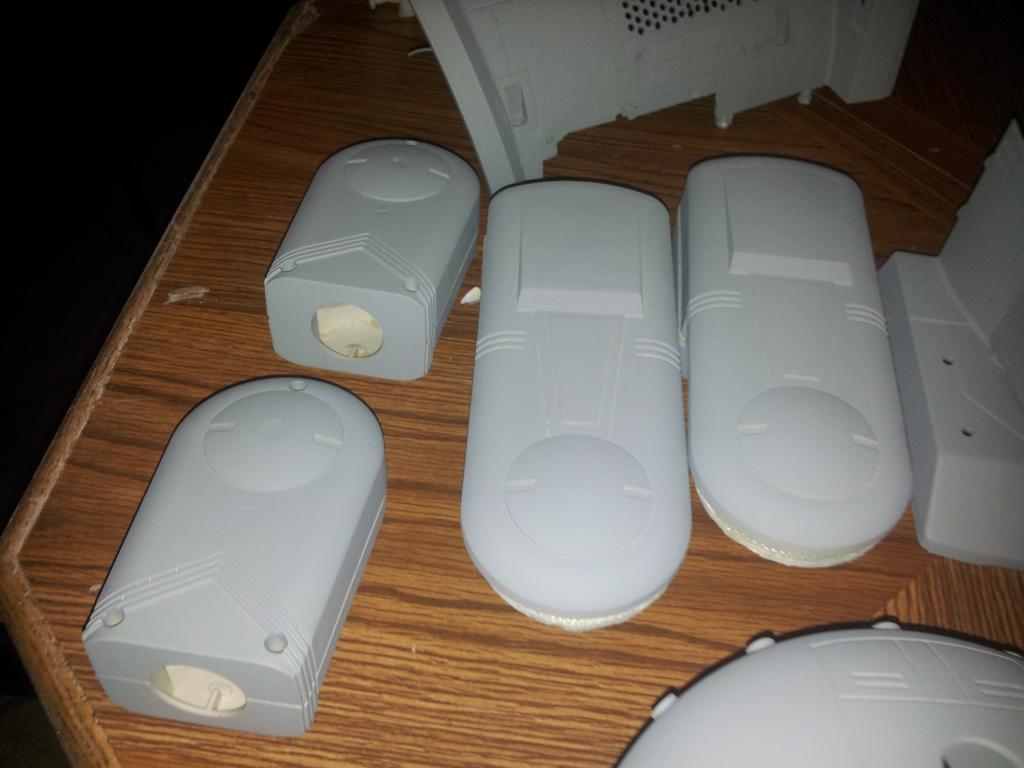
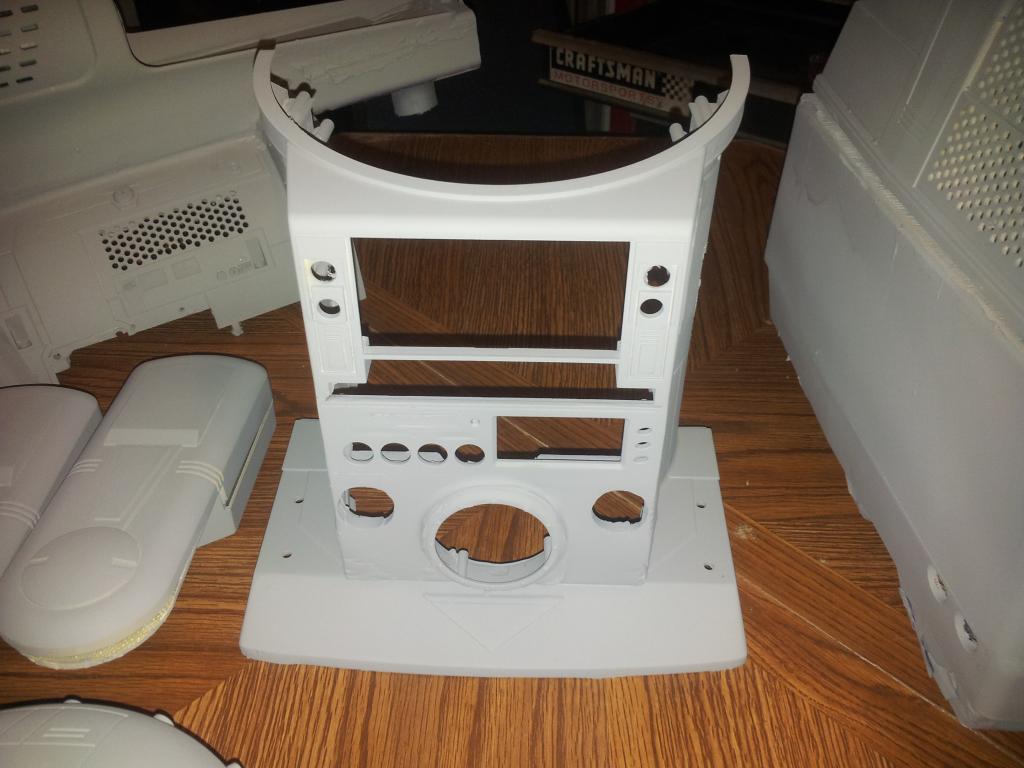
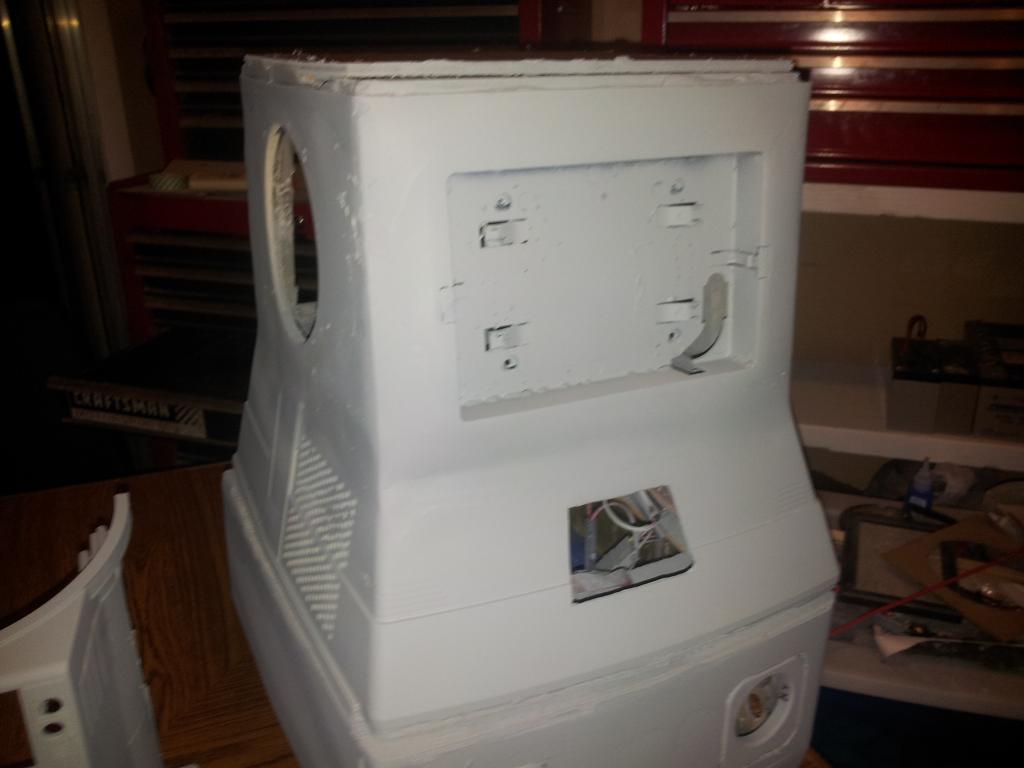
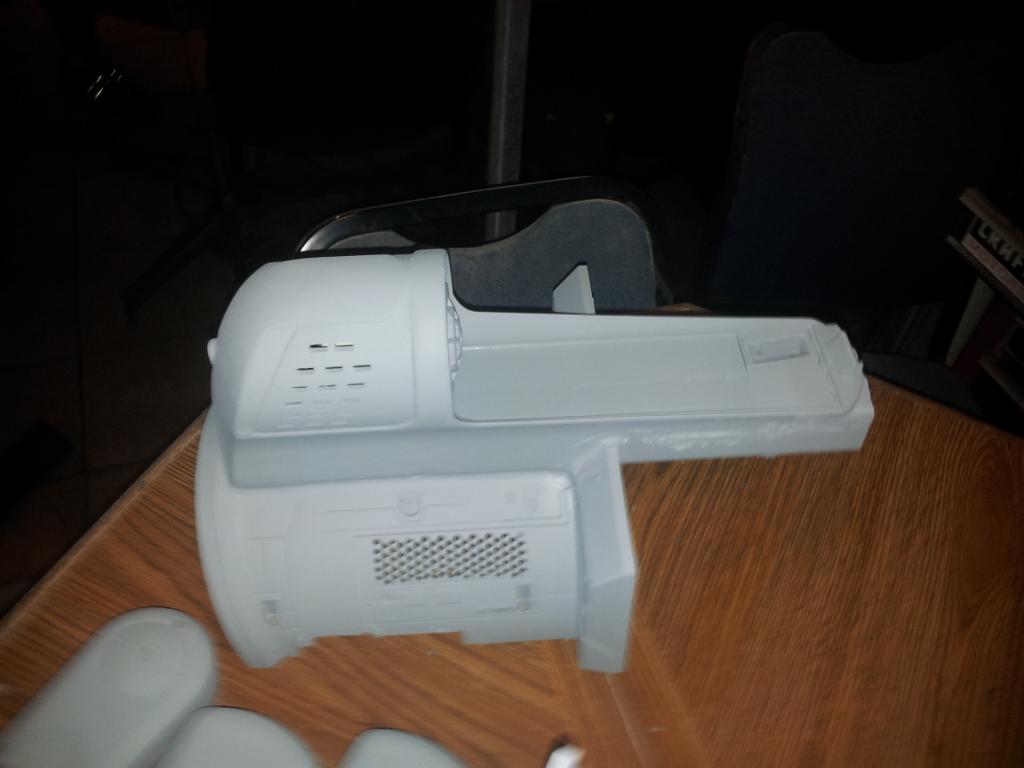
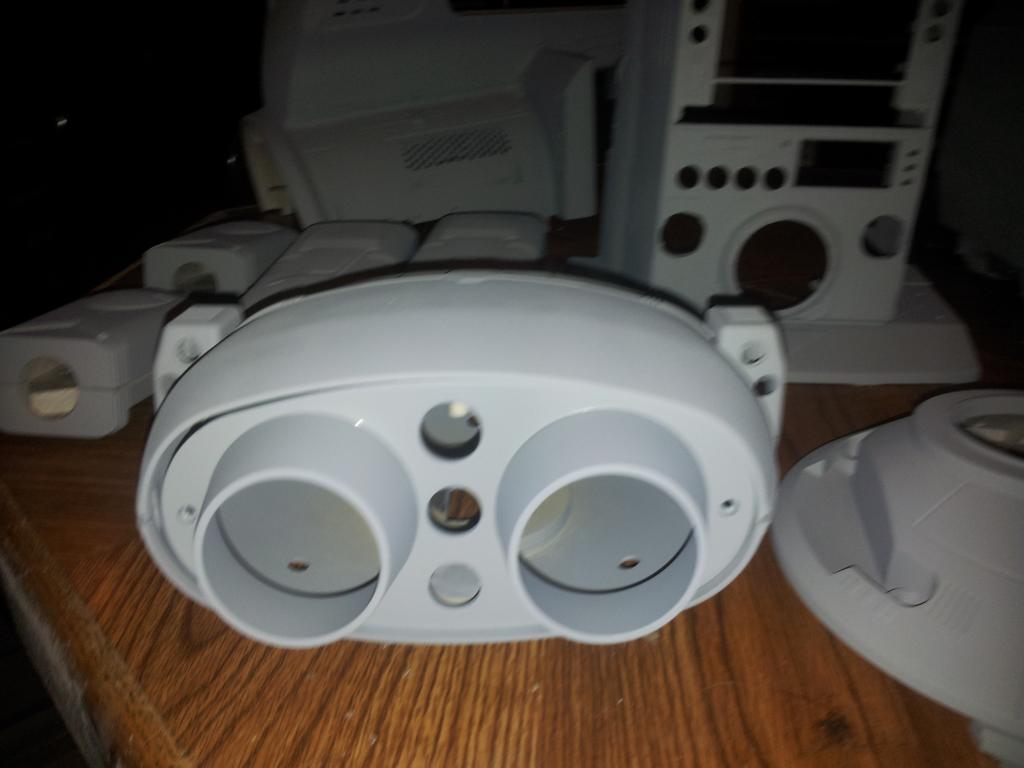
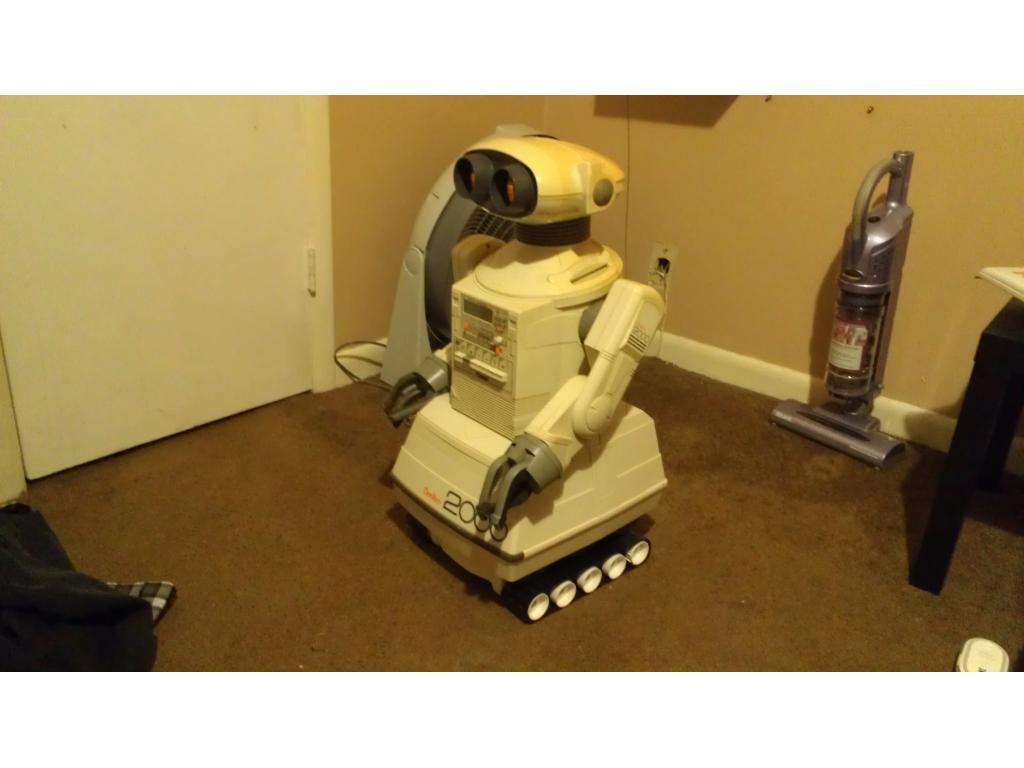
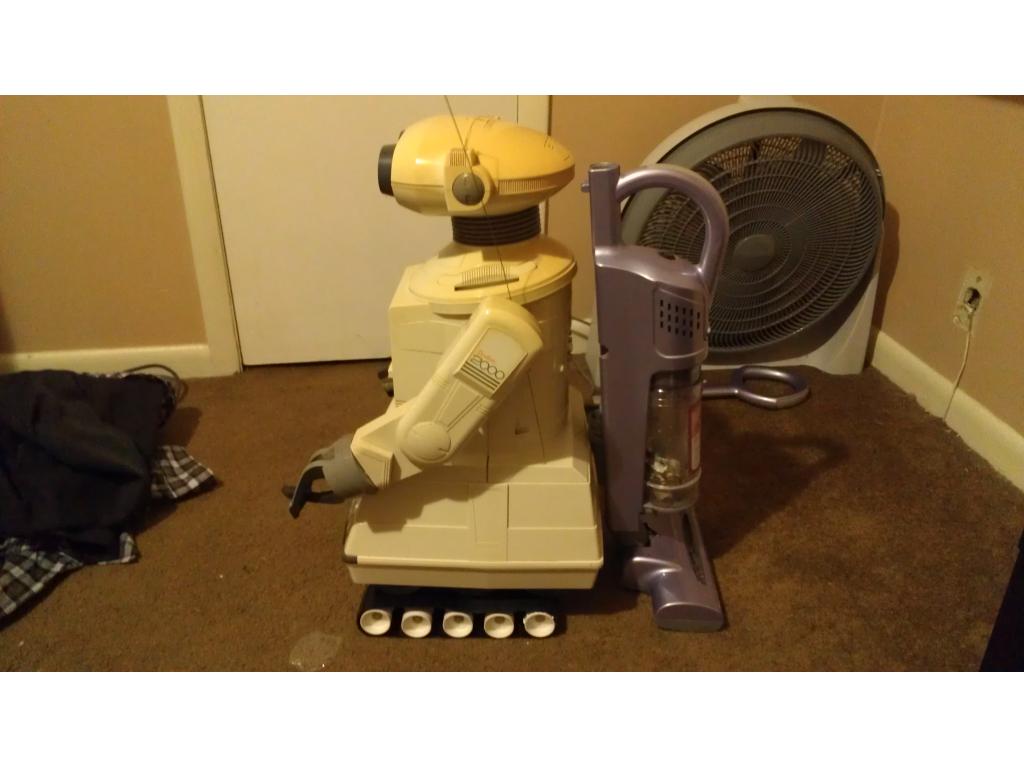
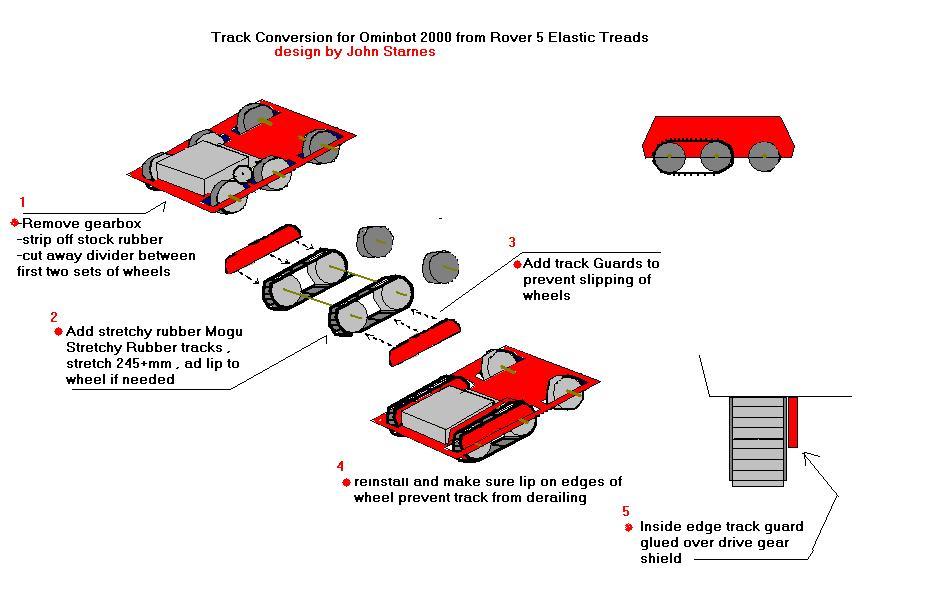
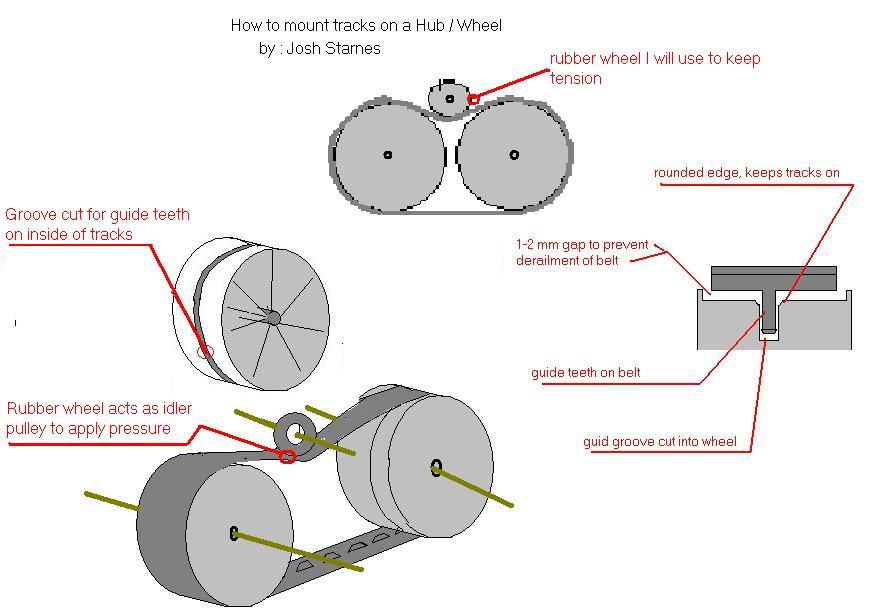
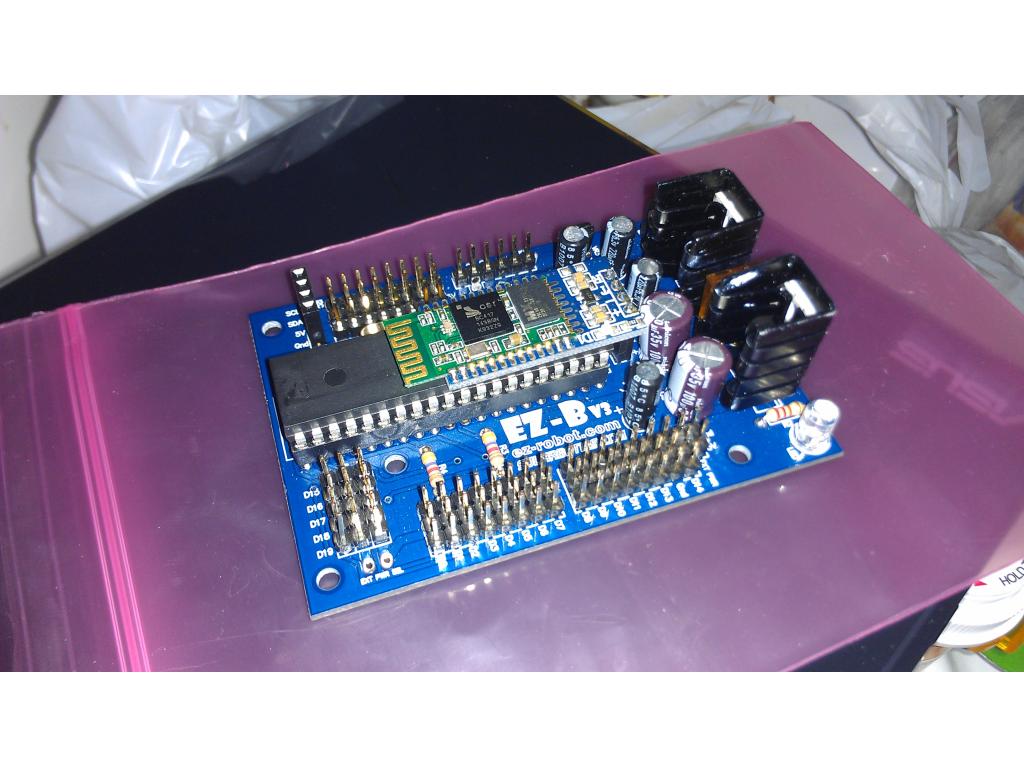
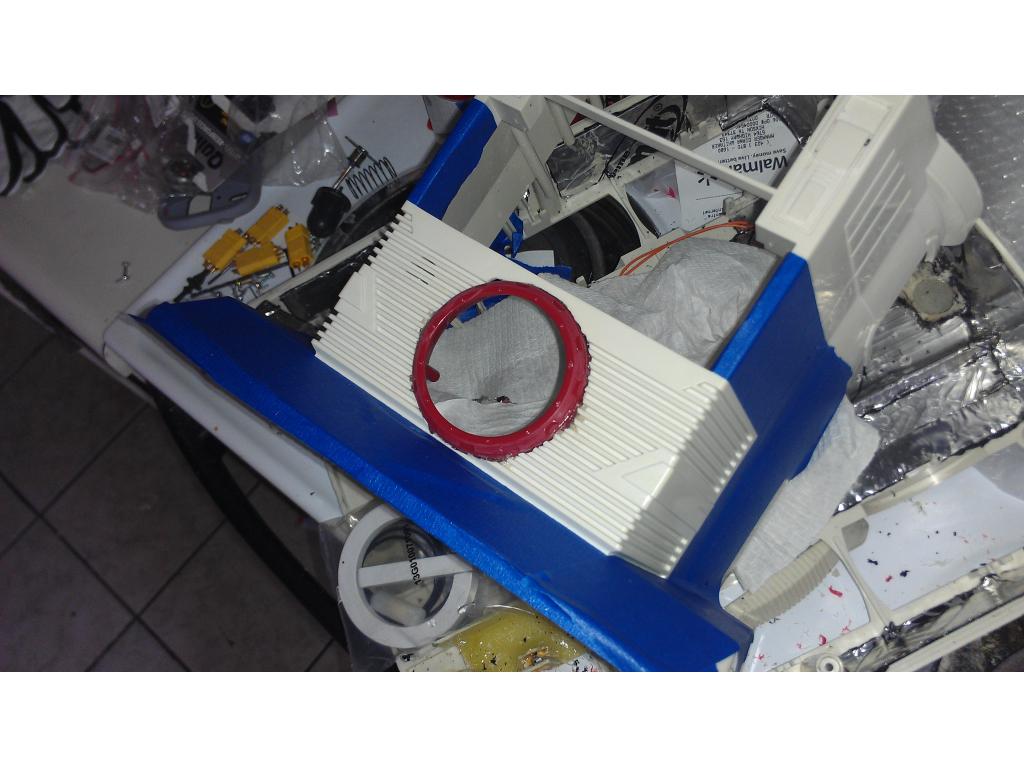
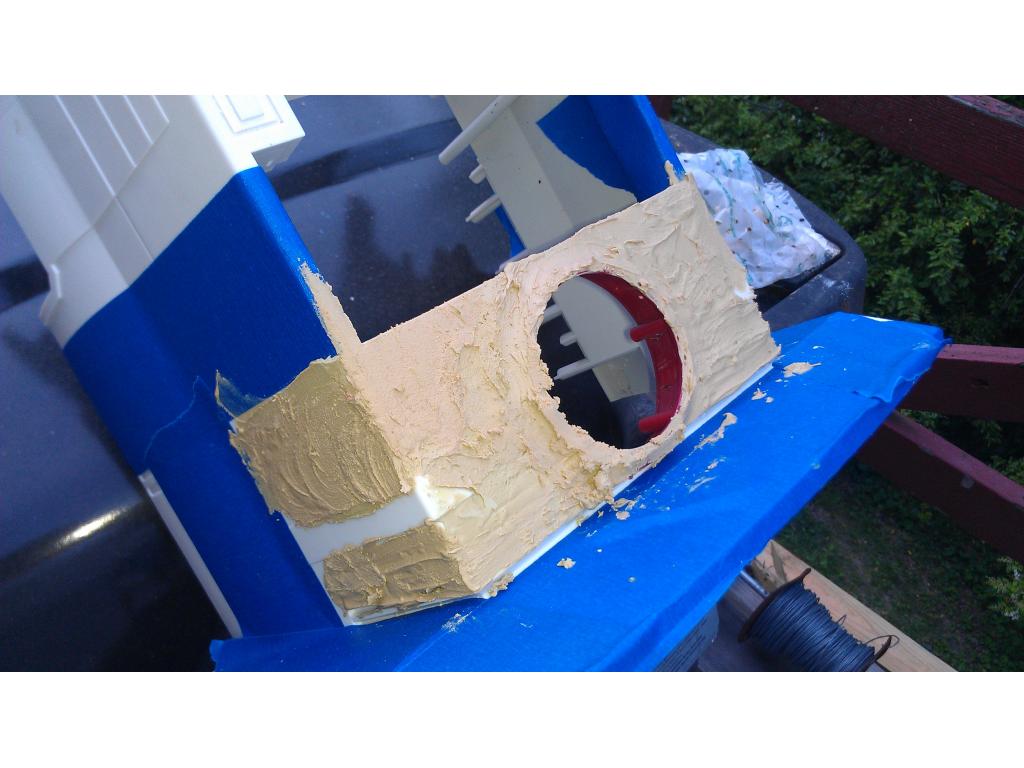
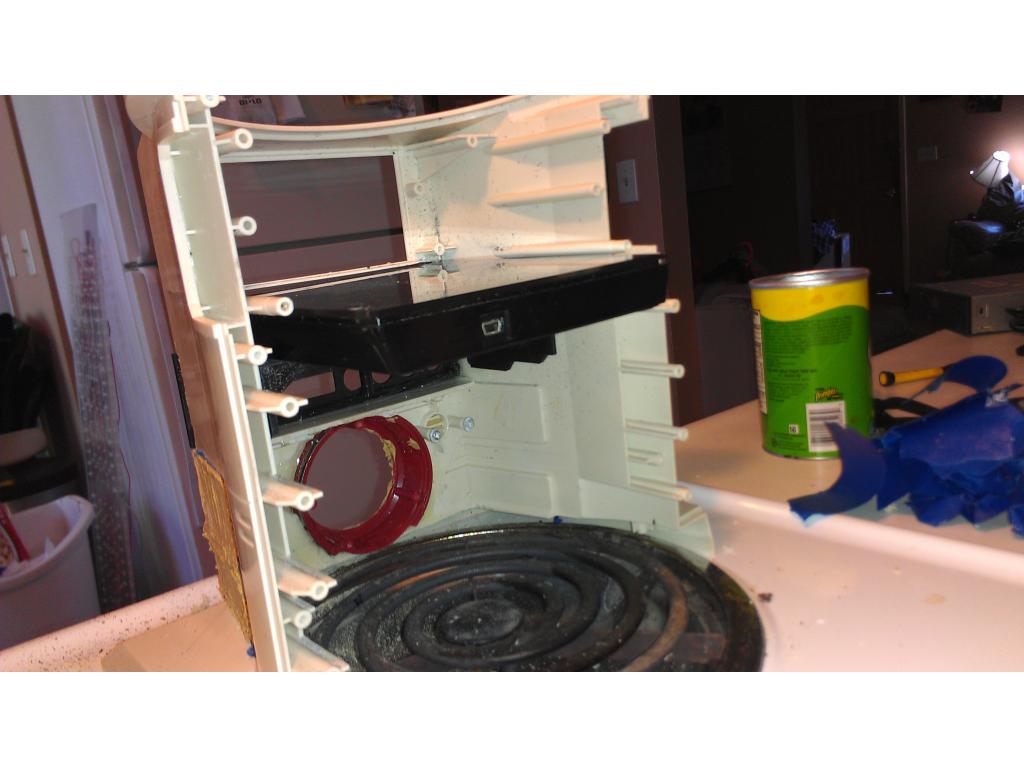
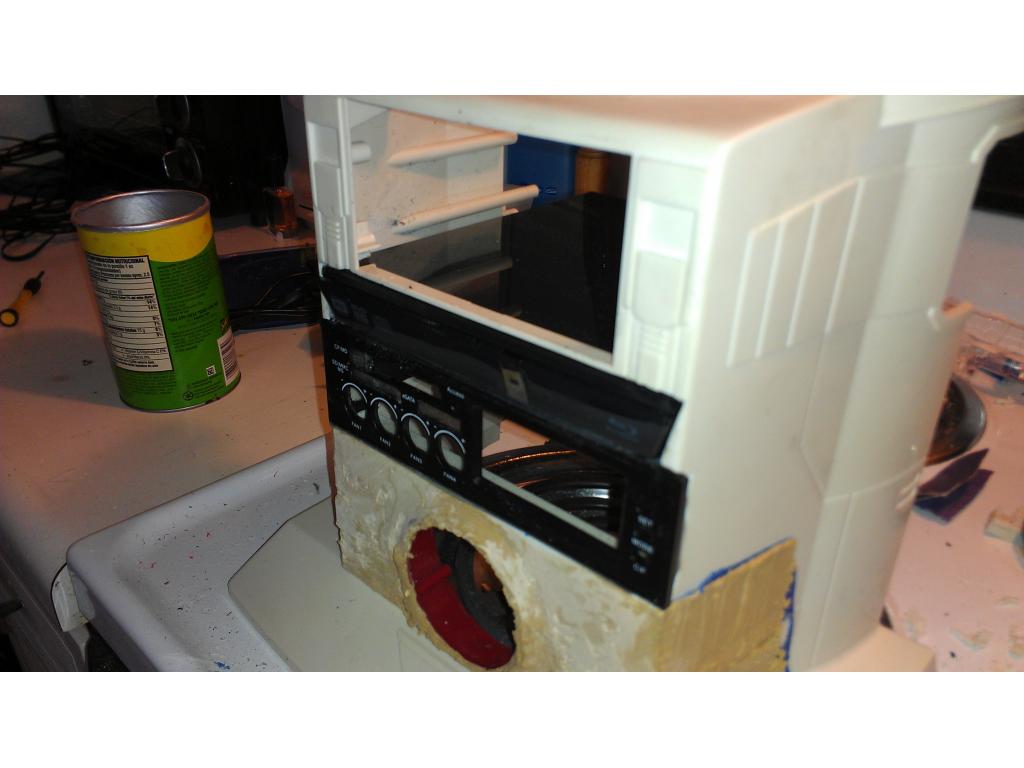
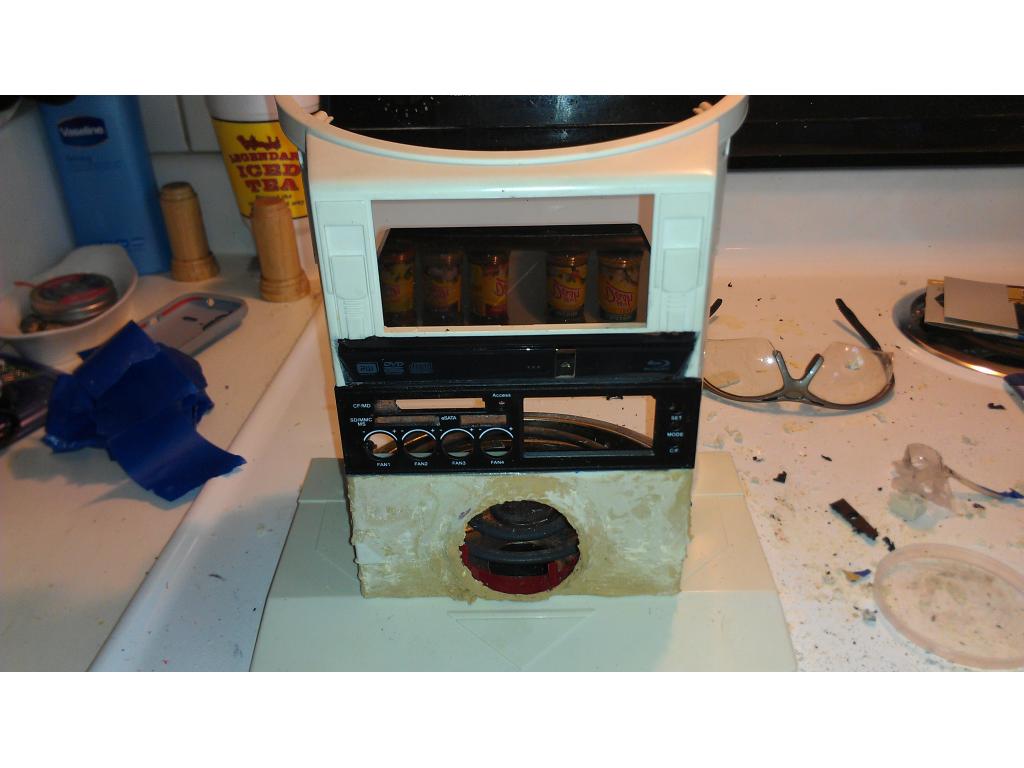
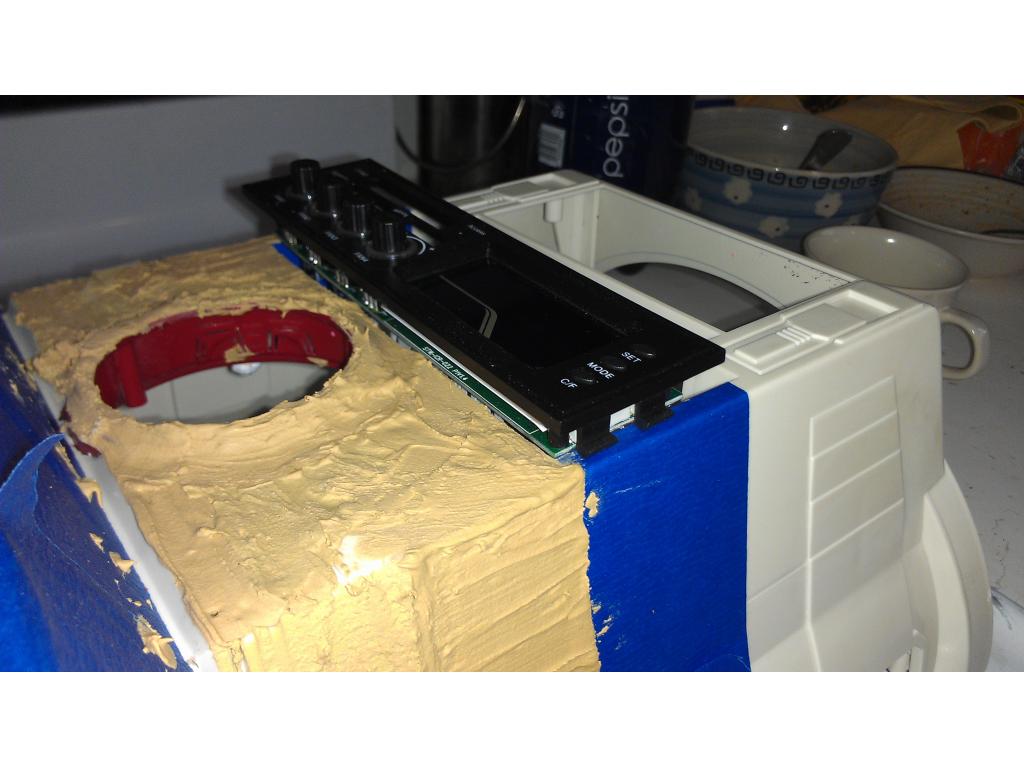
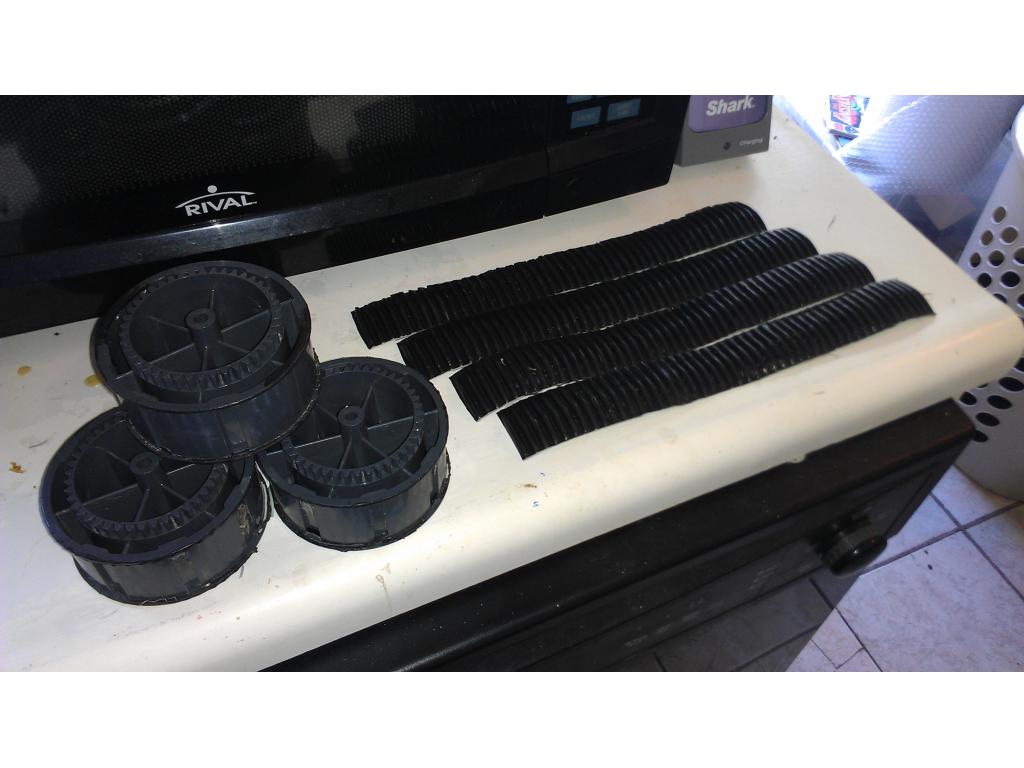
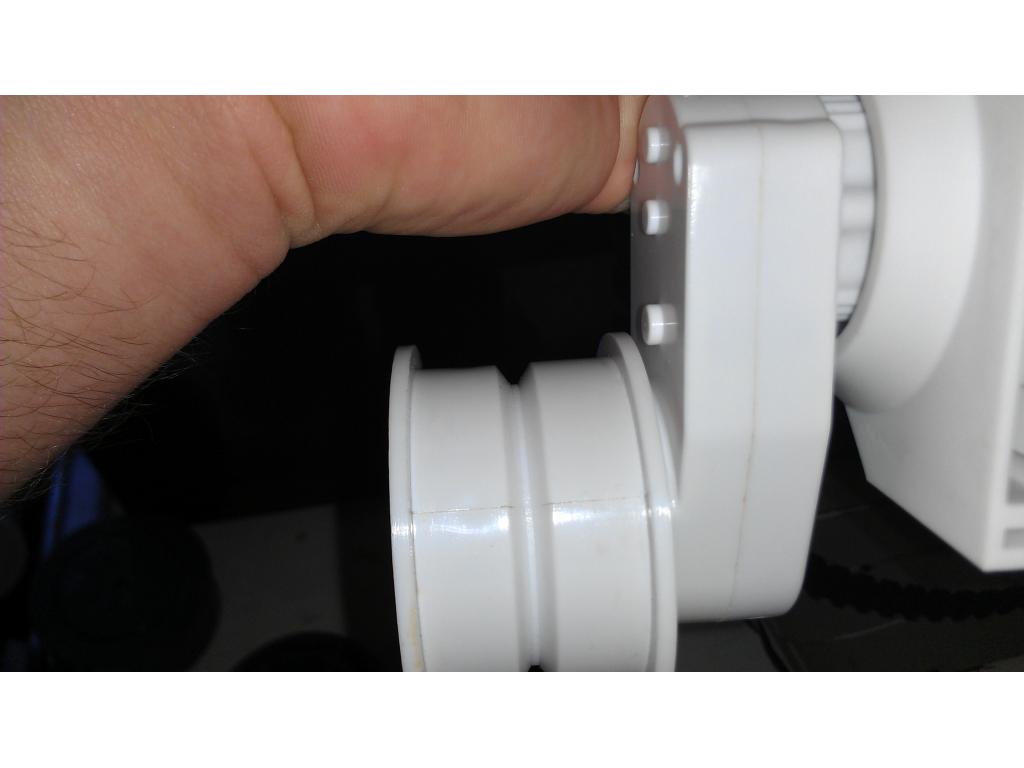
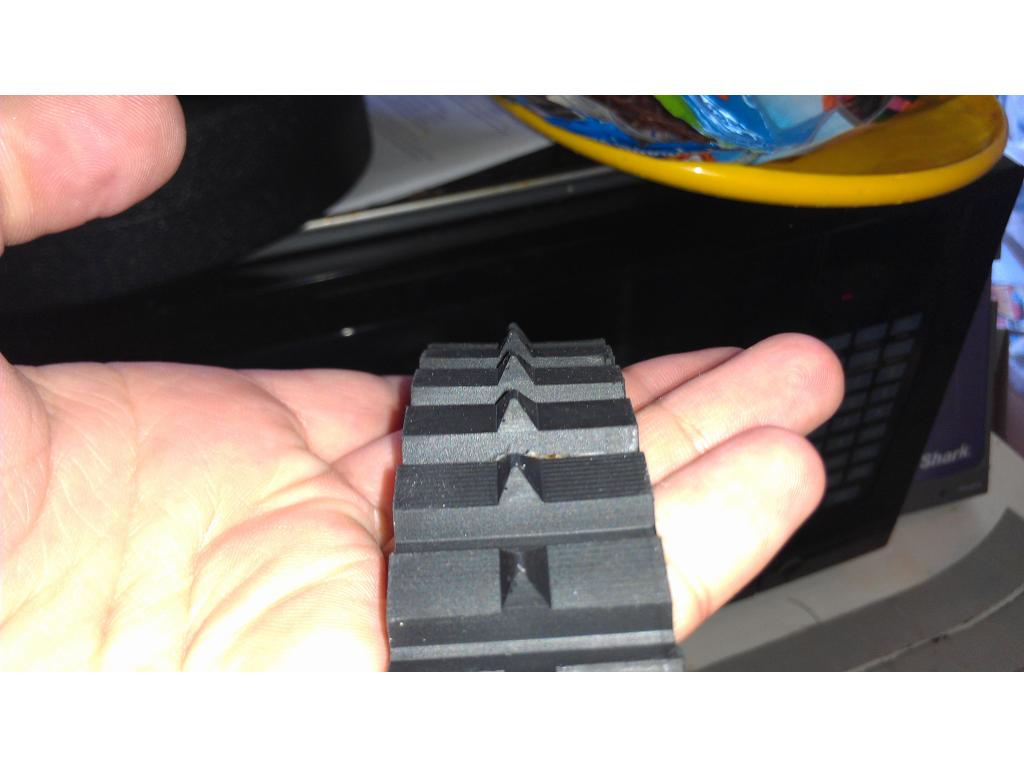
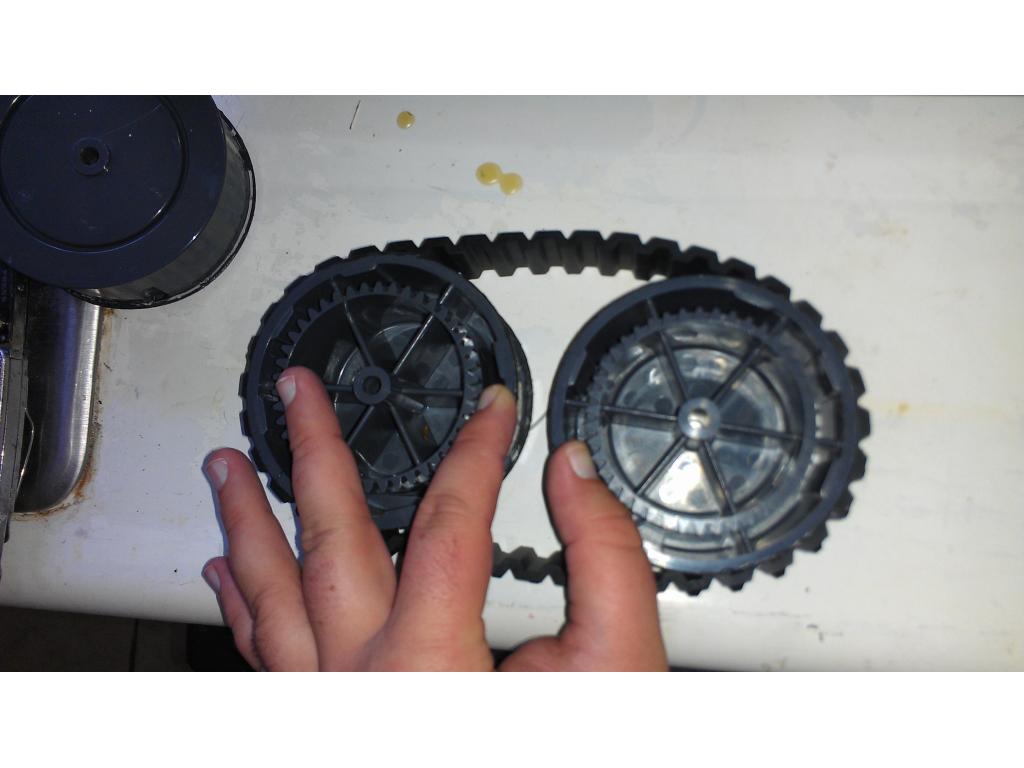
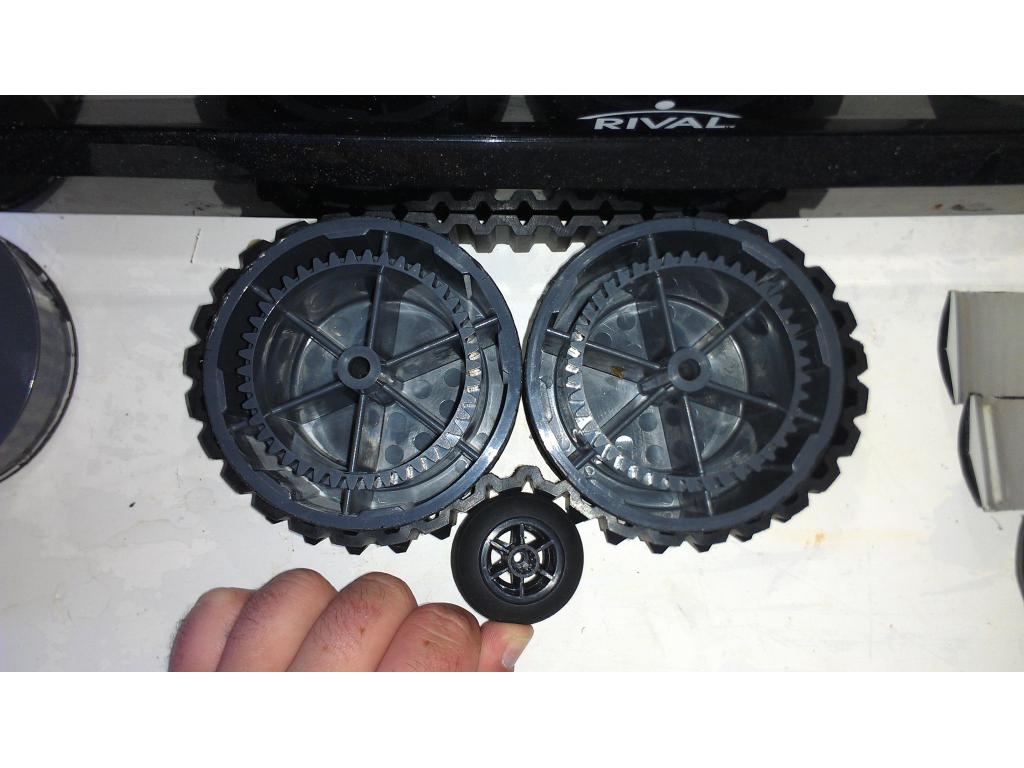
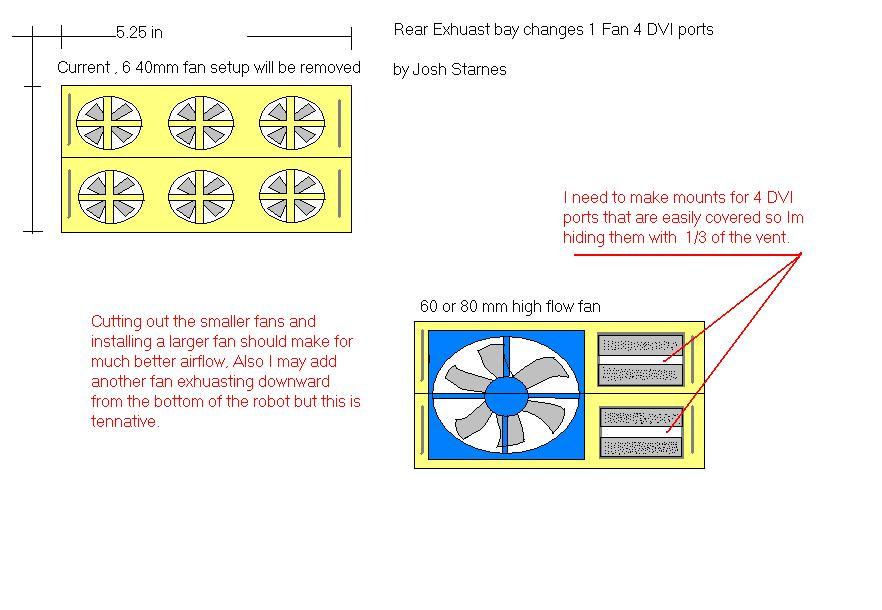
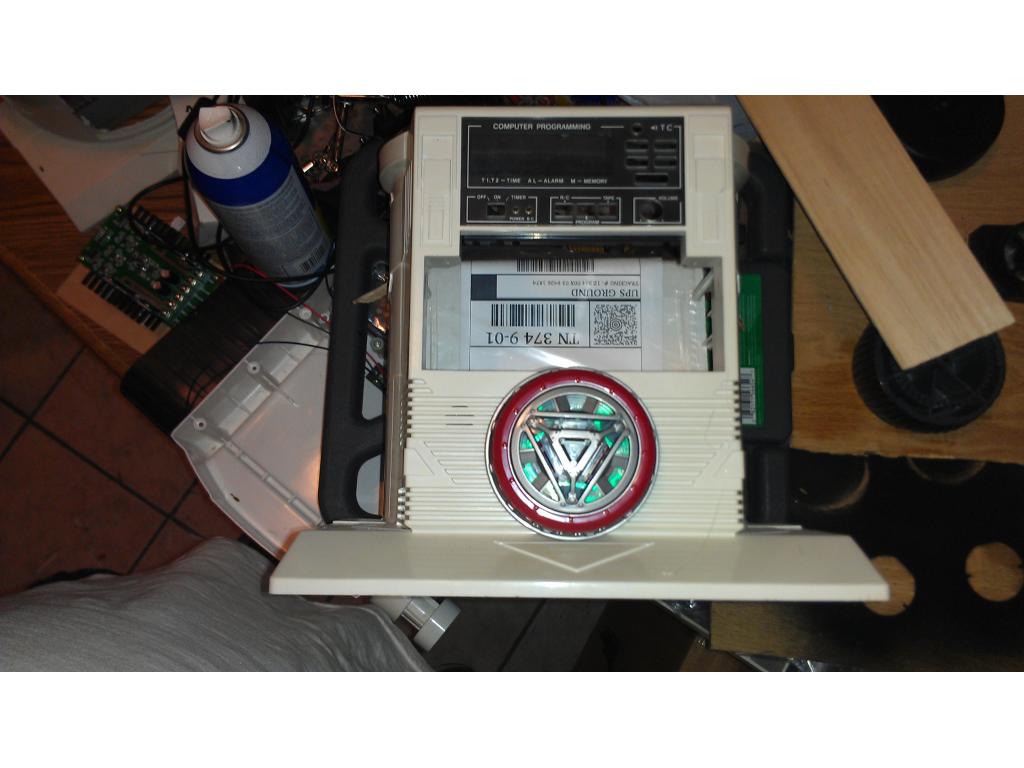
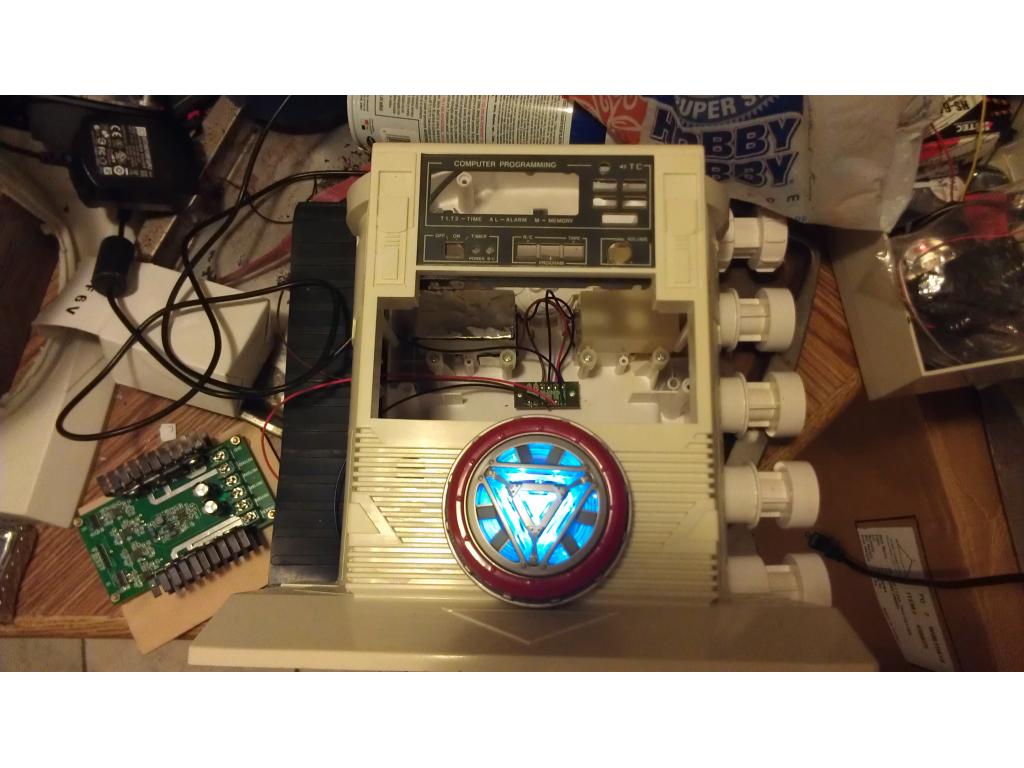
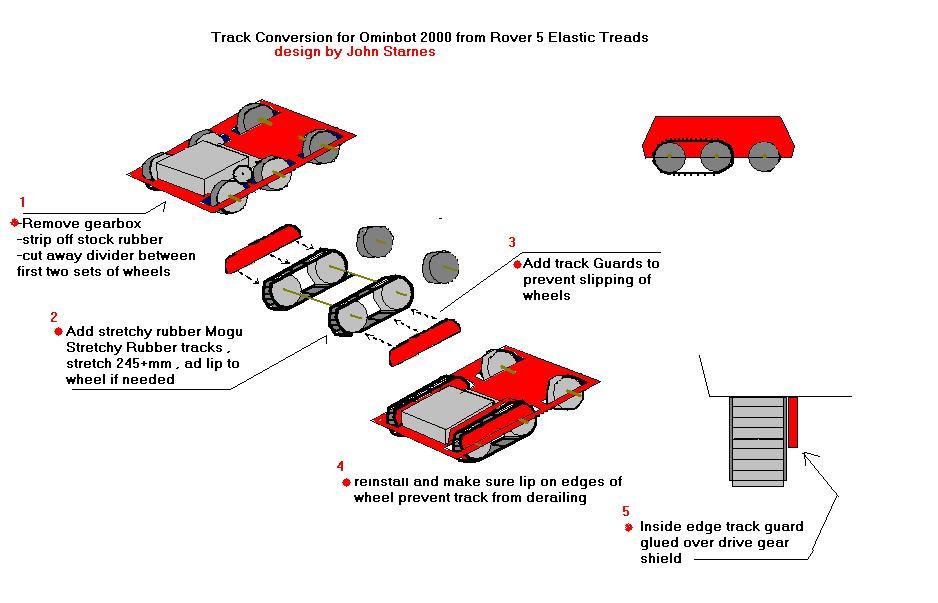
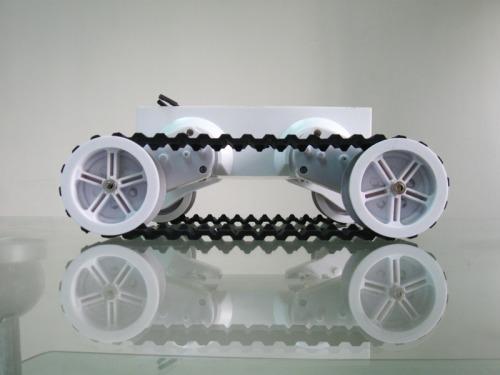
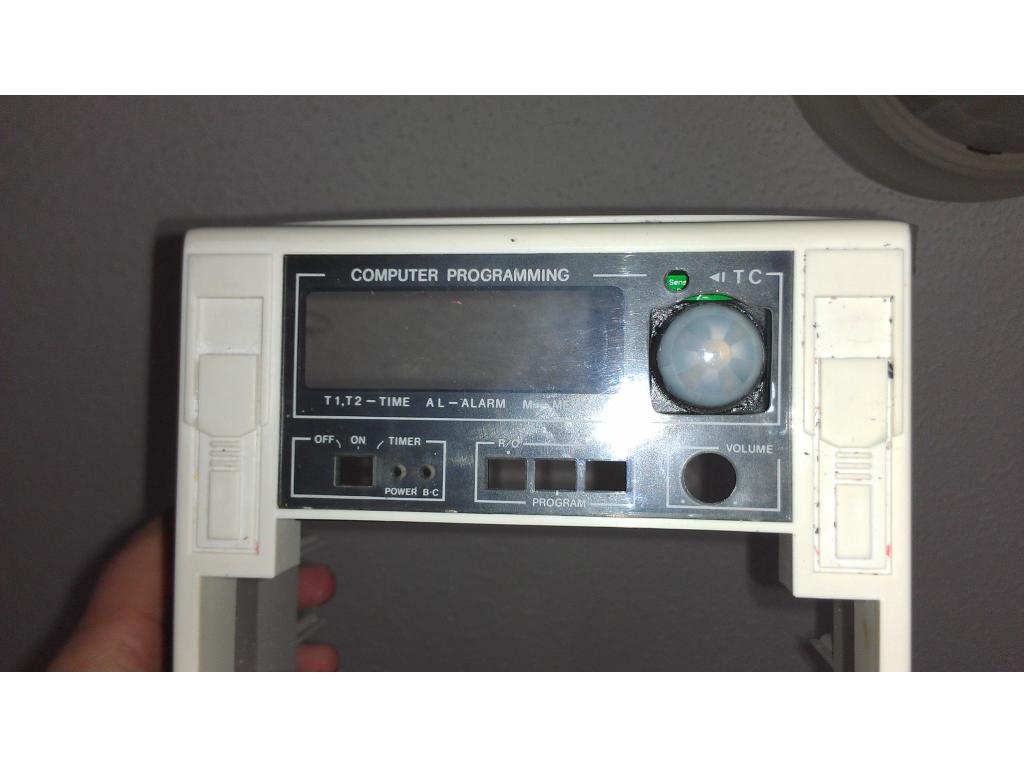
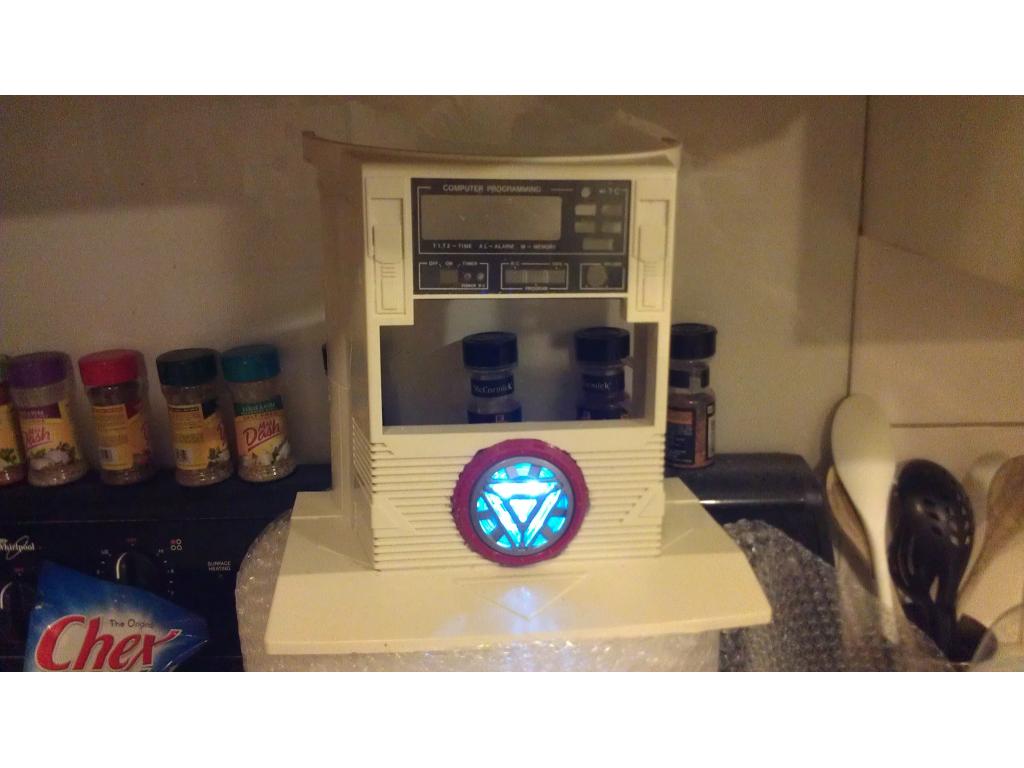
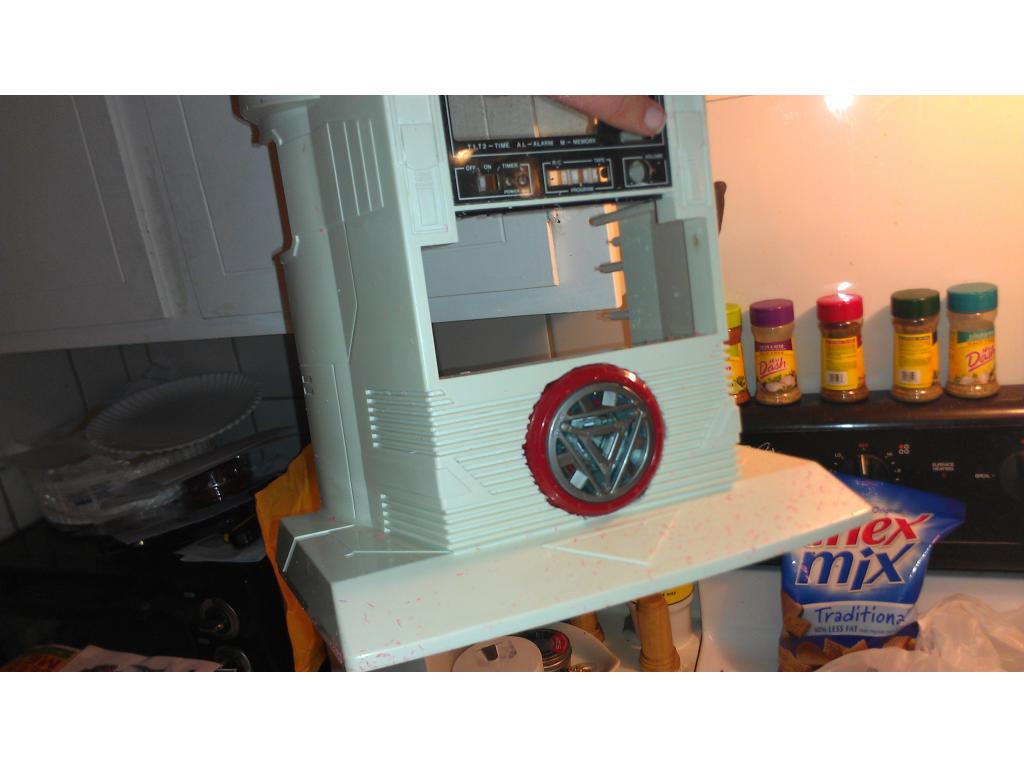
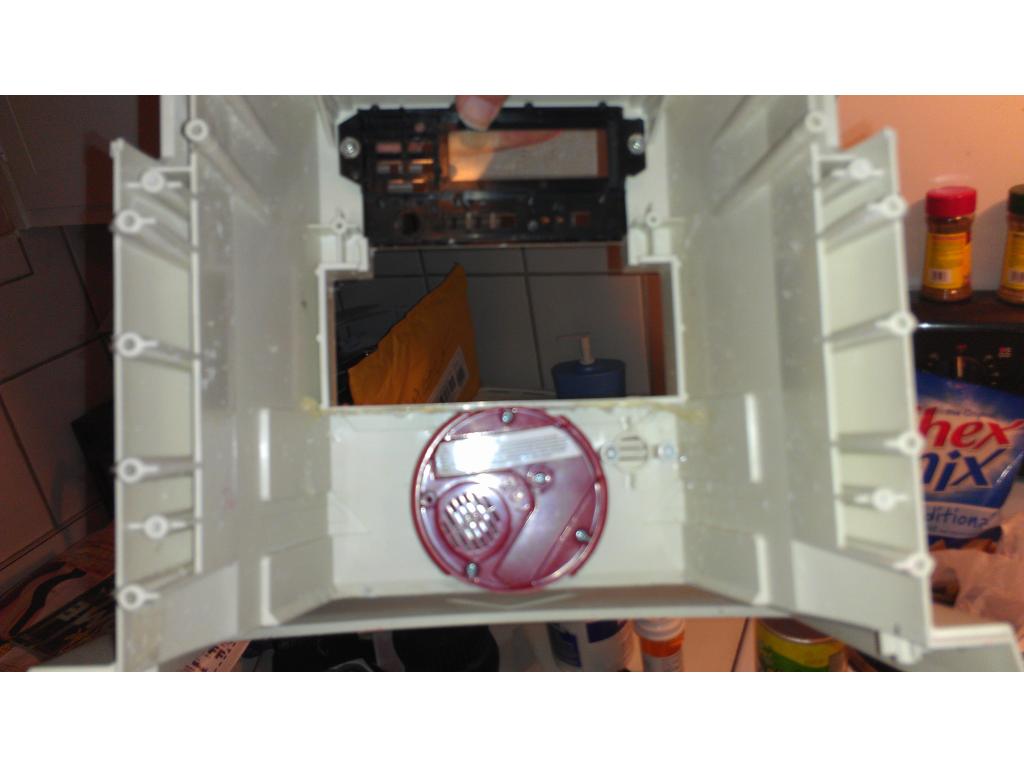
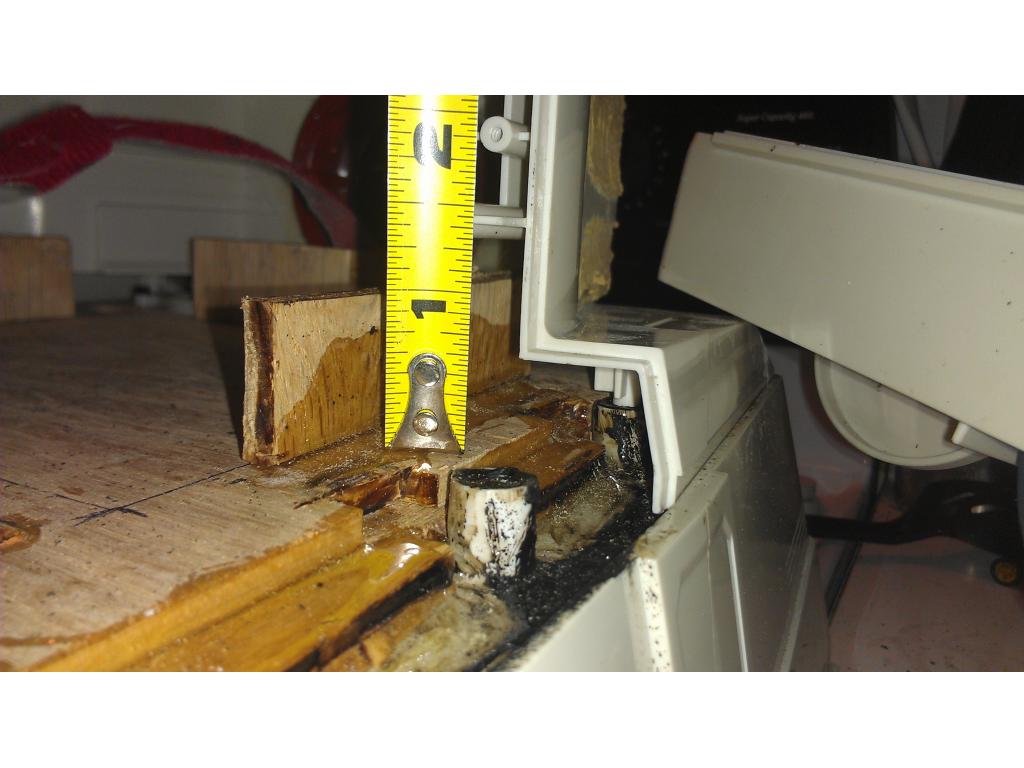
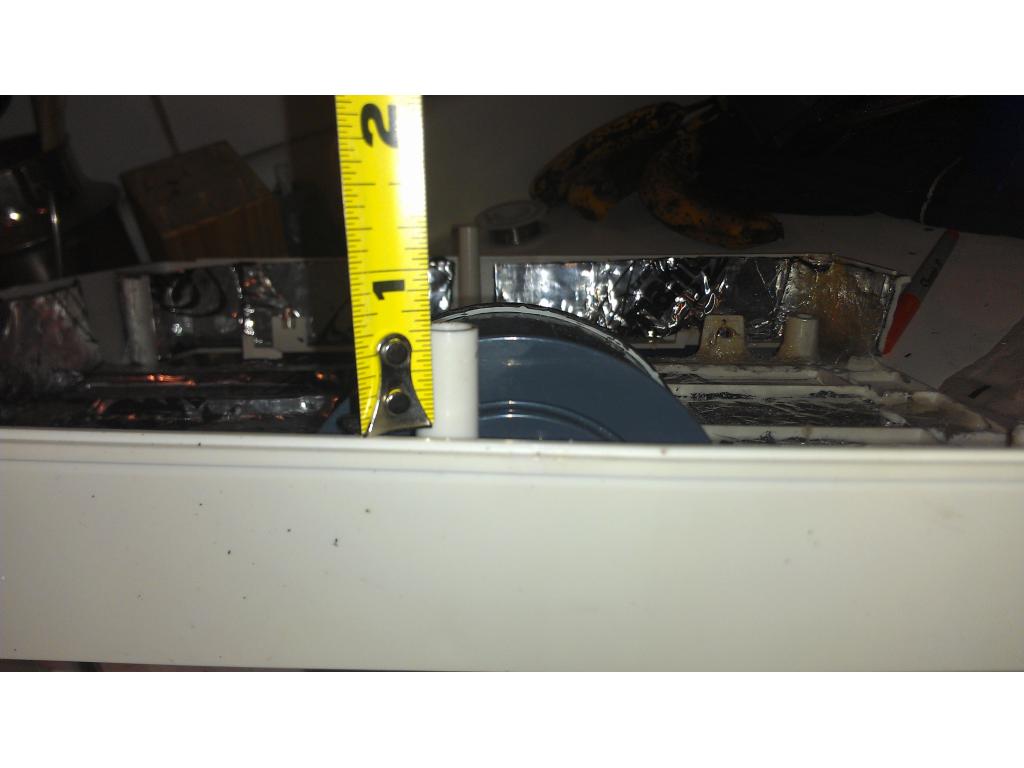
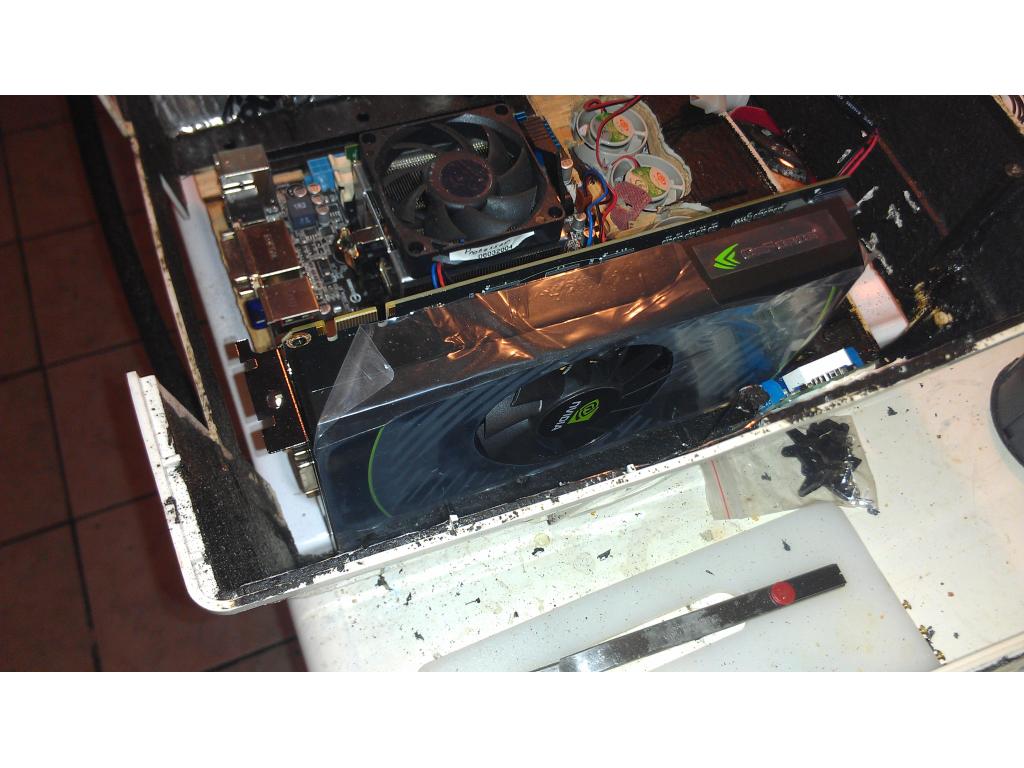
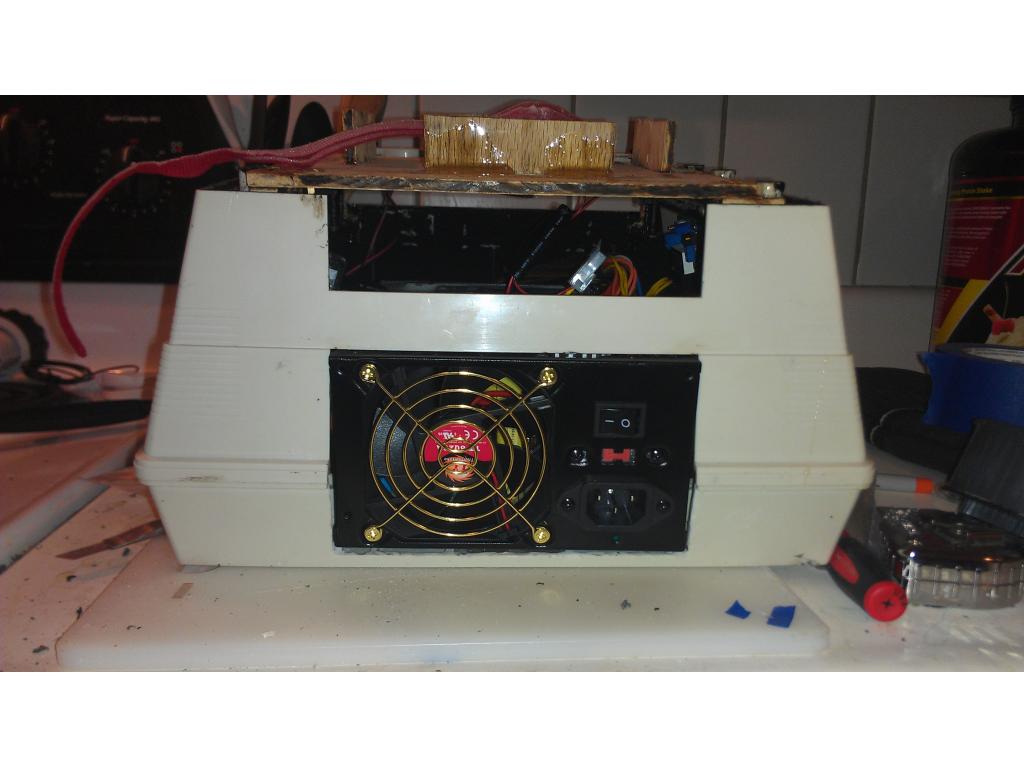
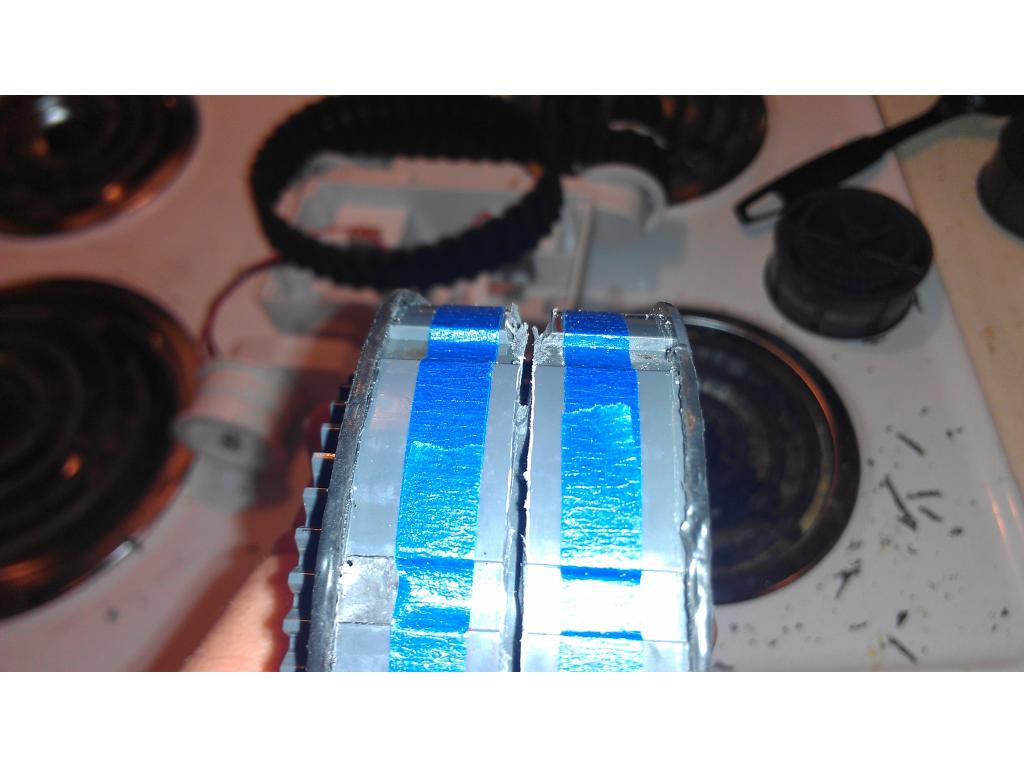
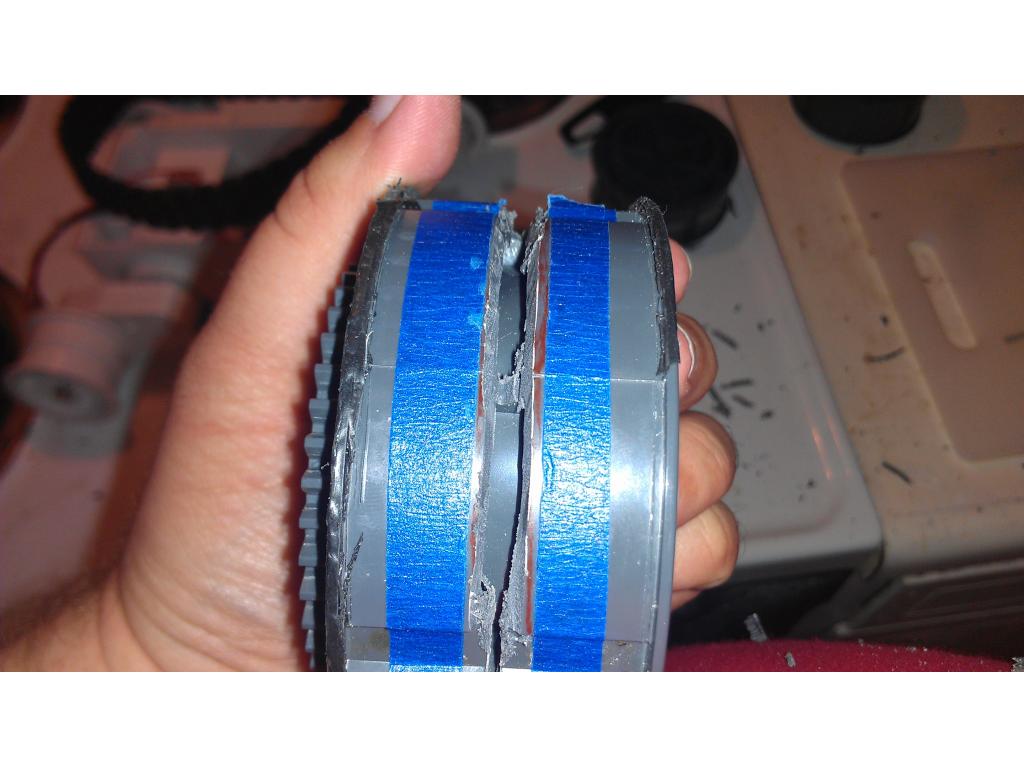
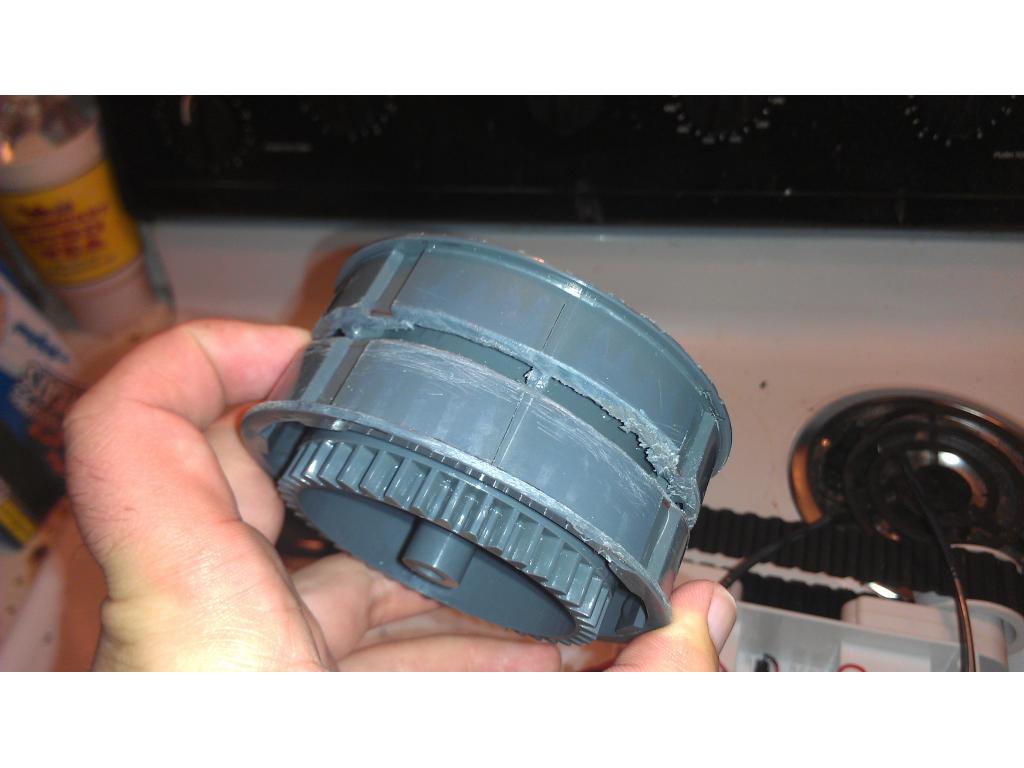
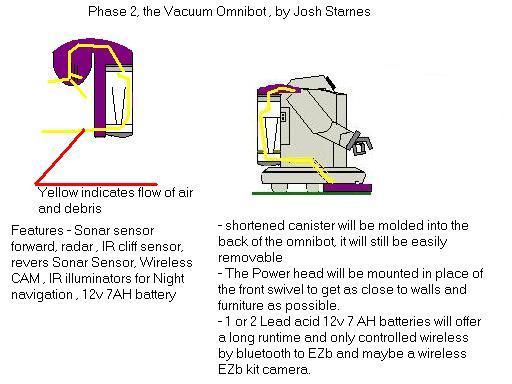
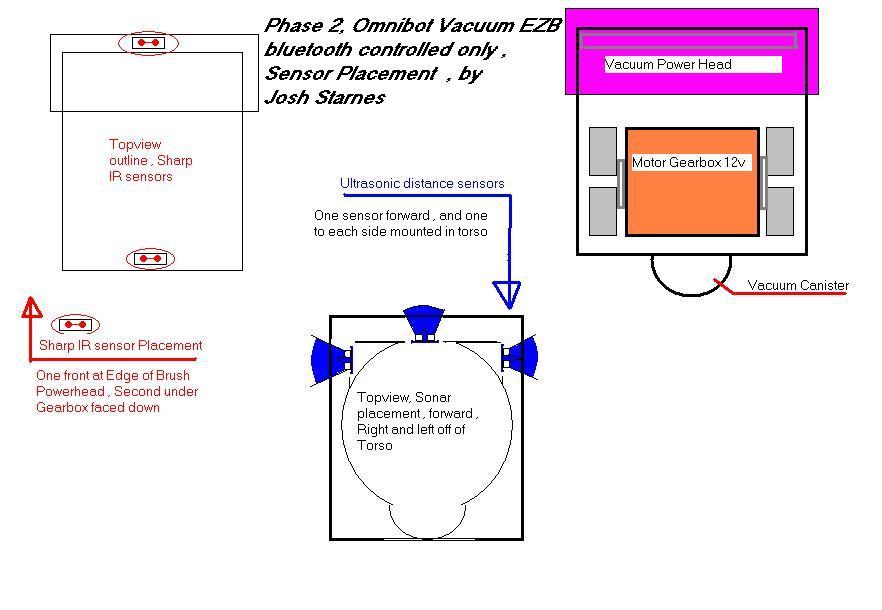
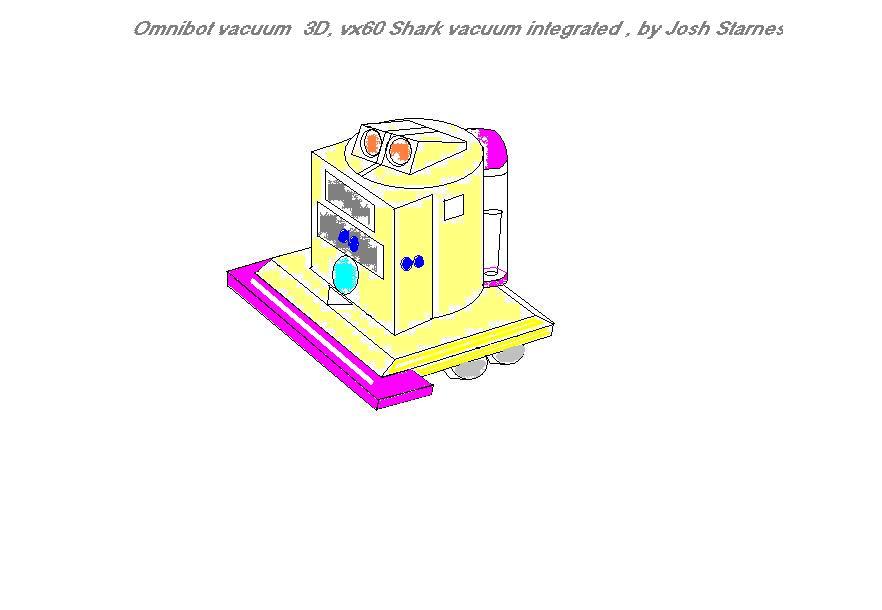
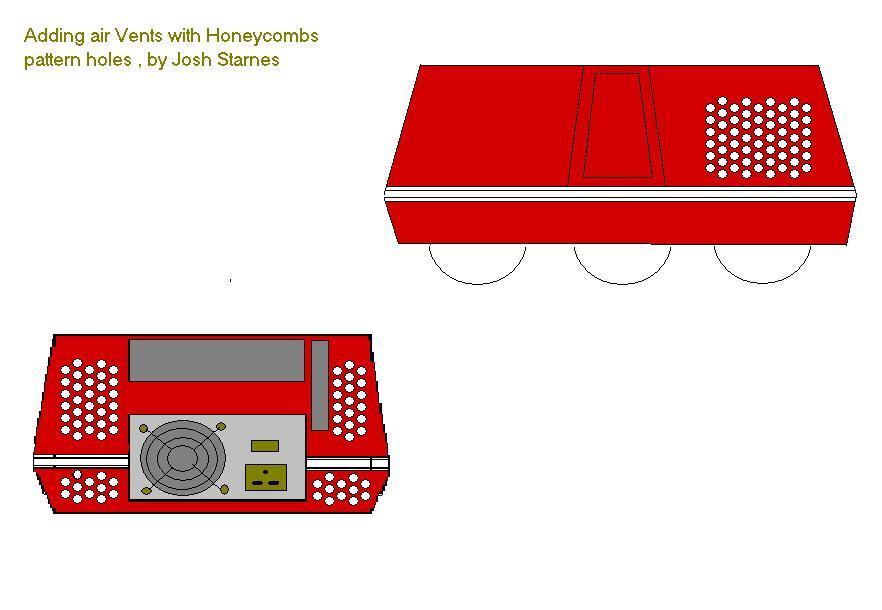
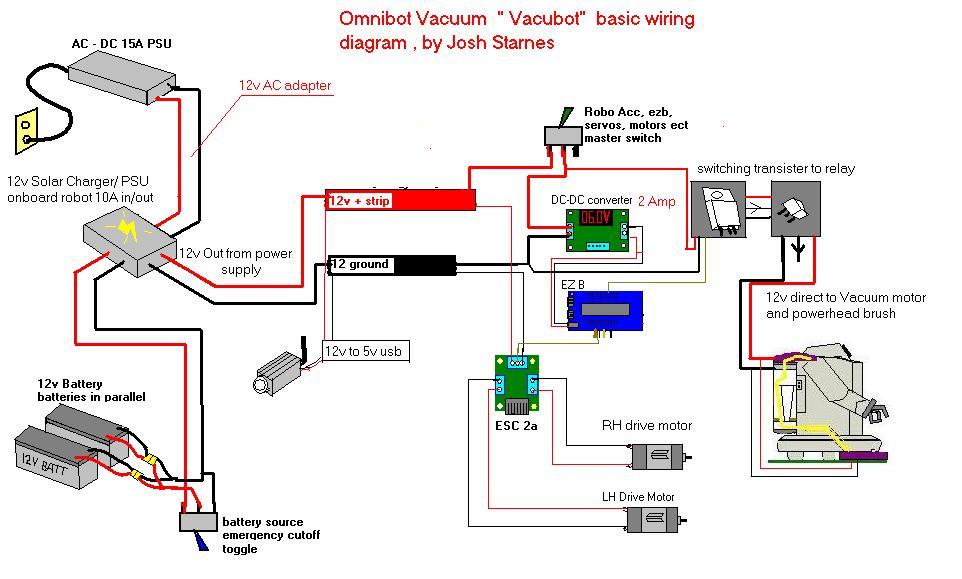
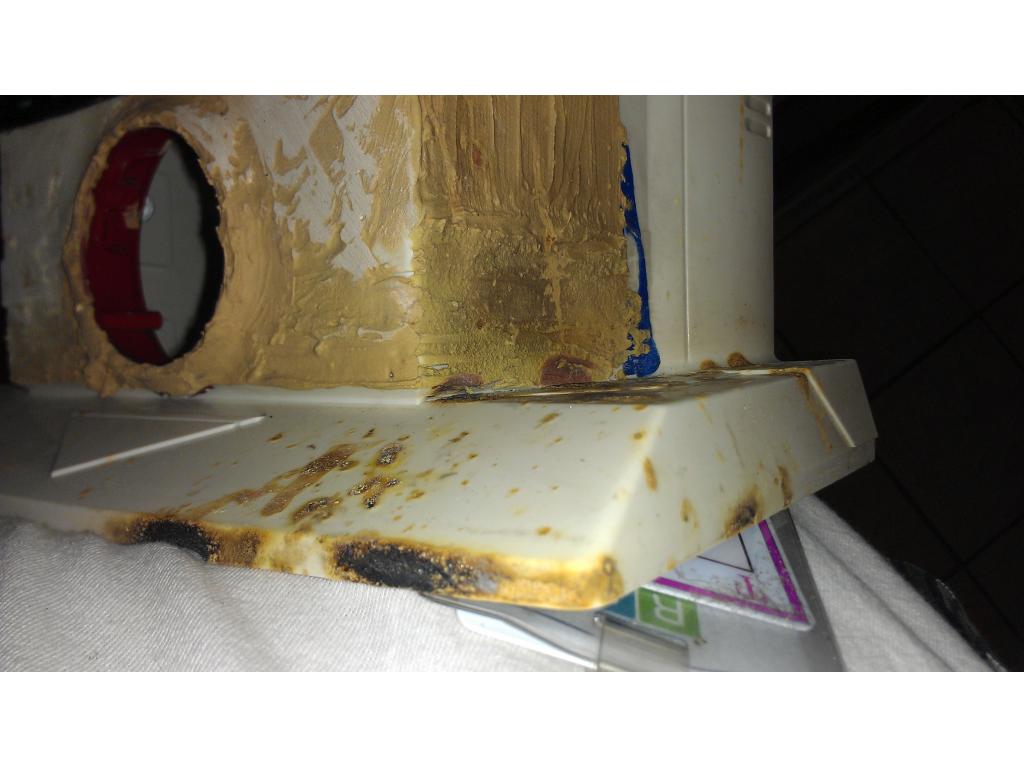
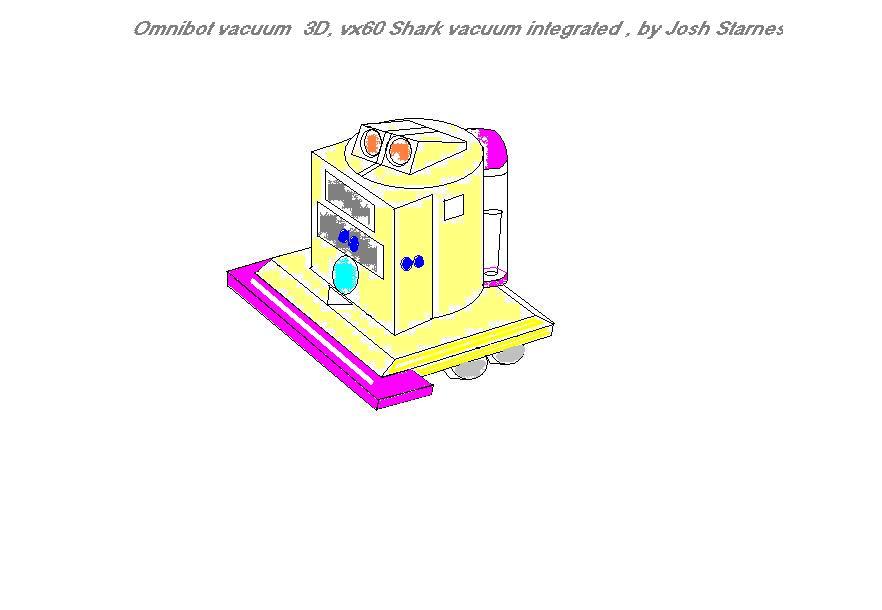
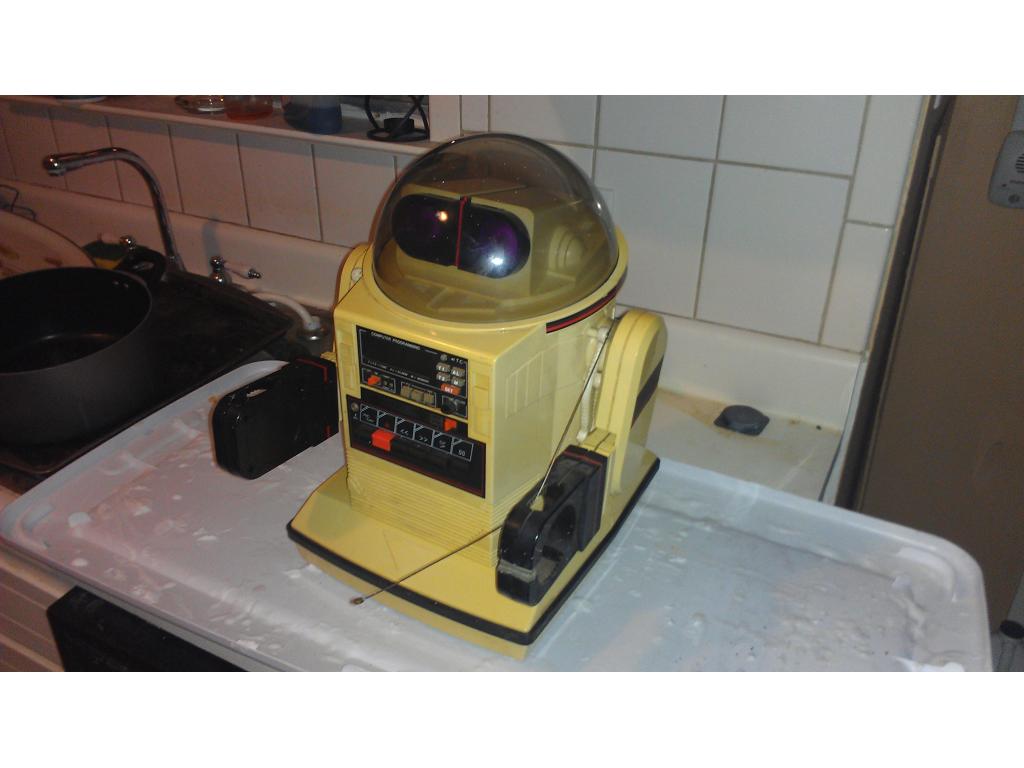
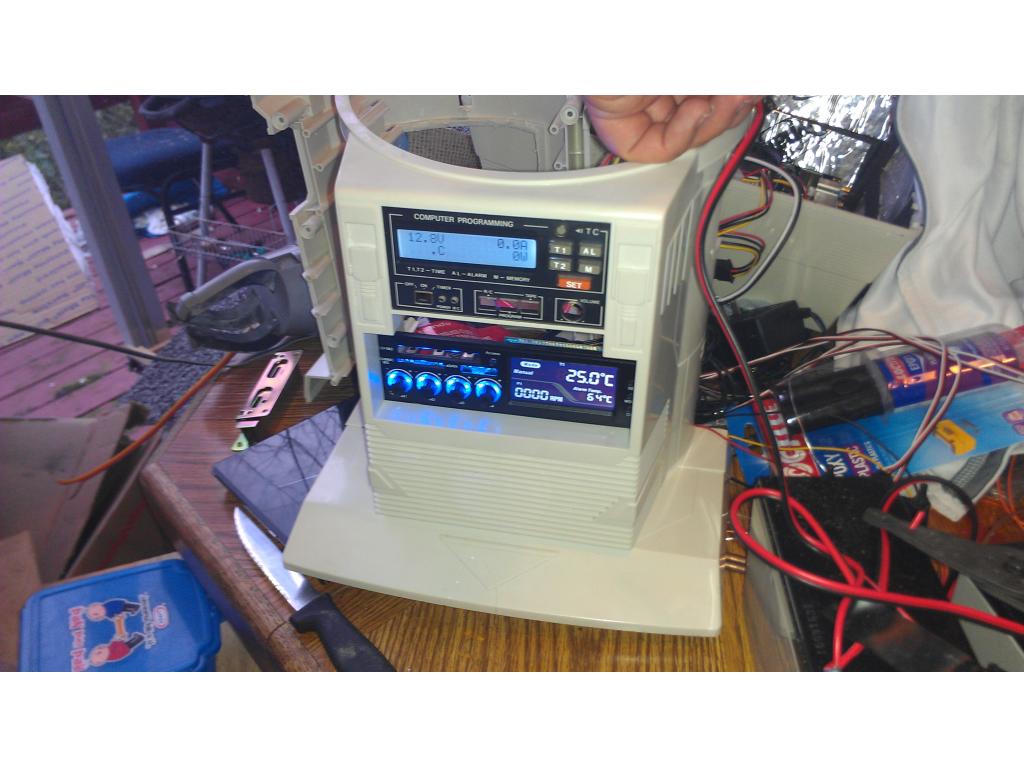
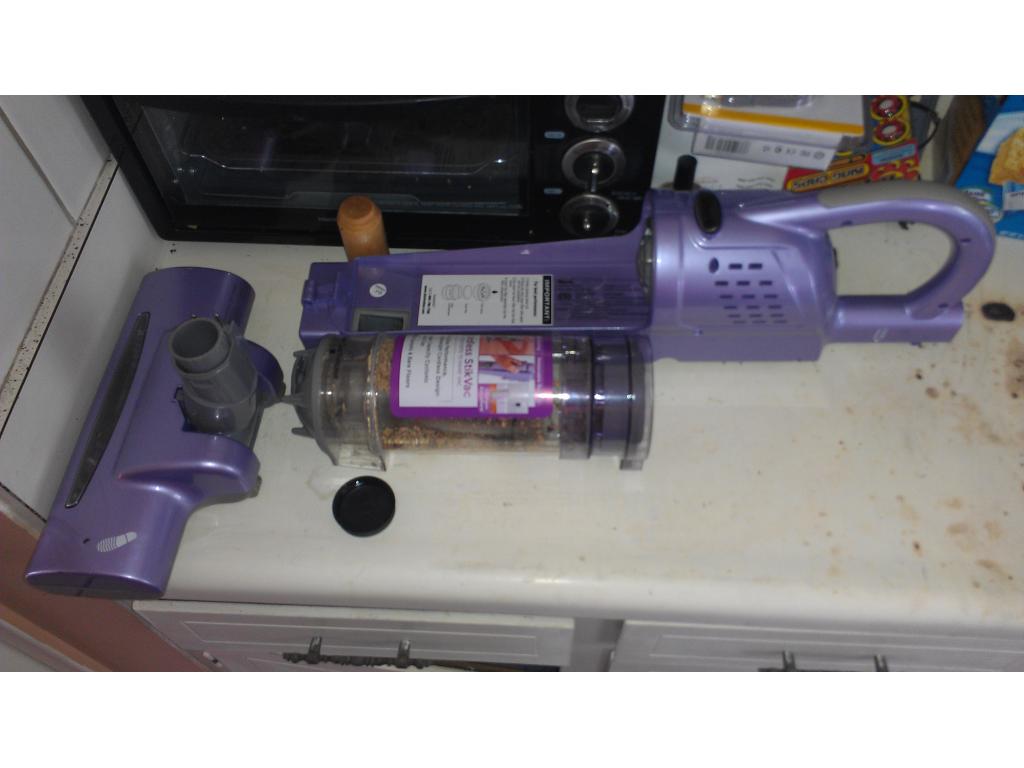
This project has evolved some , the basic rundown is I'm modding two Omnibots , one a regular the other a larger 2000 model. I will have two ezb kits , rad base idea was thrown out because of so much noise but could go back on the table if the omnibot drivetrain is too weak to pull it.

By jstarne1
— Last update

Discover more robots
DJ's Master Blaster Robot
Remote-controlled 1980s-style animatronic robot with servos for arms/head and wheeled mobility, controlled via Synthiam...
Cliffordkoperski's HAL THE ROBOT THAT WALKS AND TALKS
5.5ft humanoid walks, talks-56 servos on 3 EZB v4 boards via WiFi, two batteries, onboard PC; Synthiam ARC scripting...
Ezang's Happy New Year To All From Ezang And Family And...
Happy New Year from EzAng, family and Roman the robot, grateful to robot friends for teaching so much and promising more...

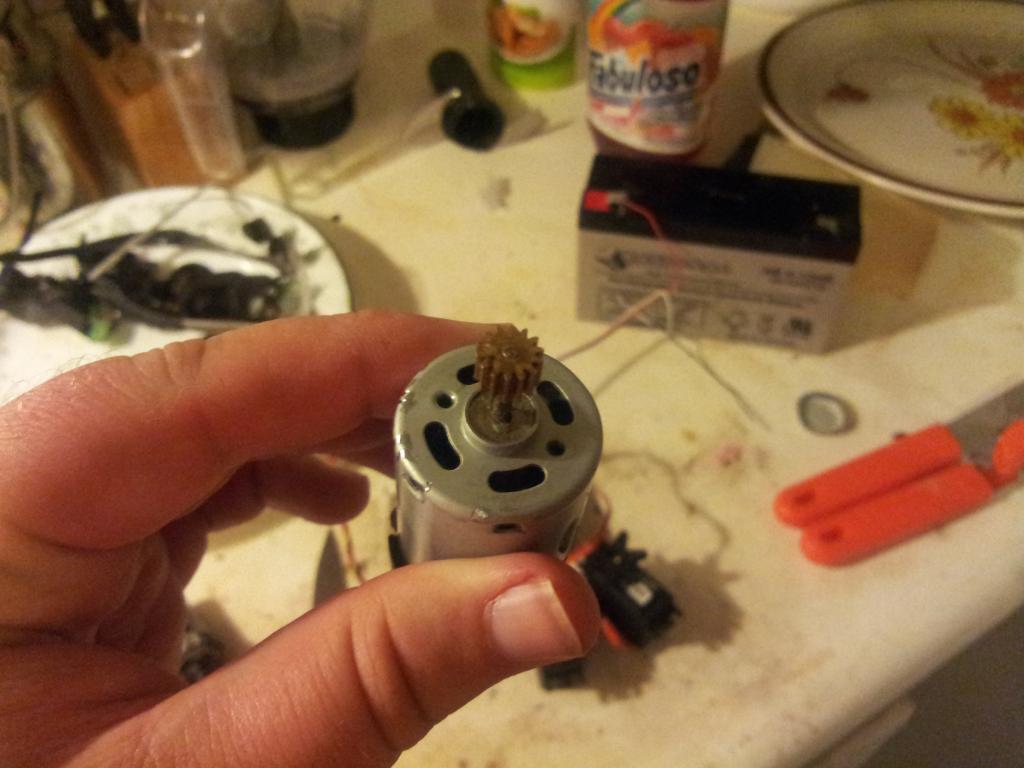
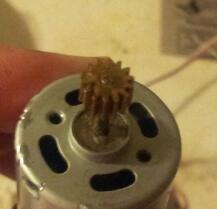
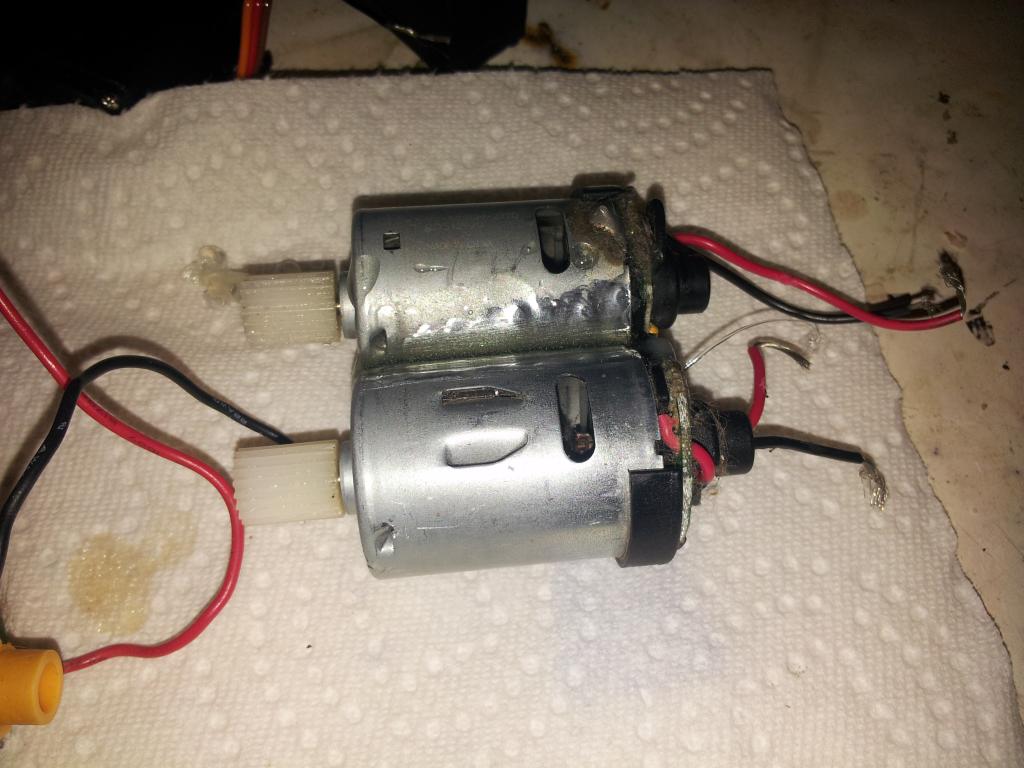
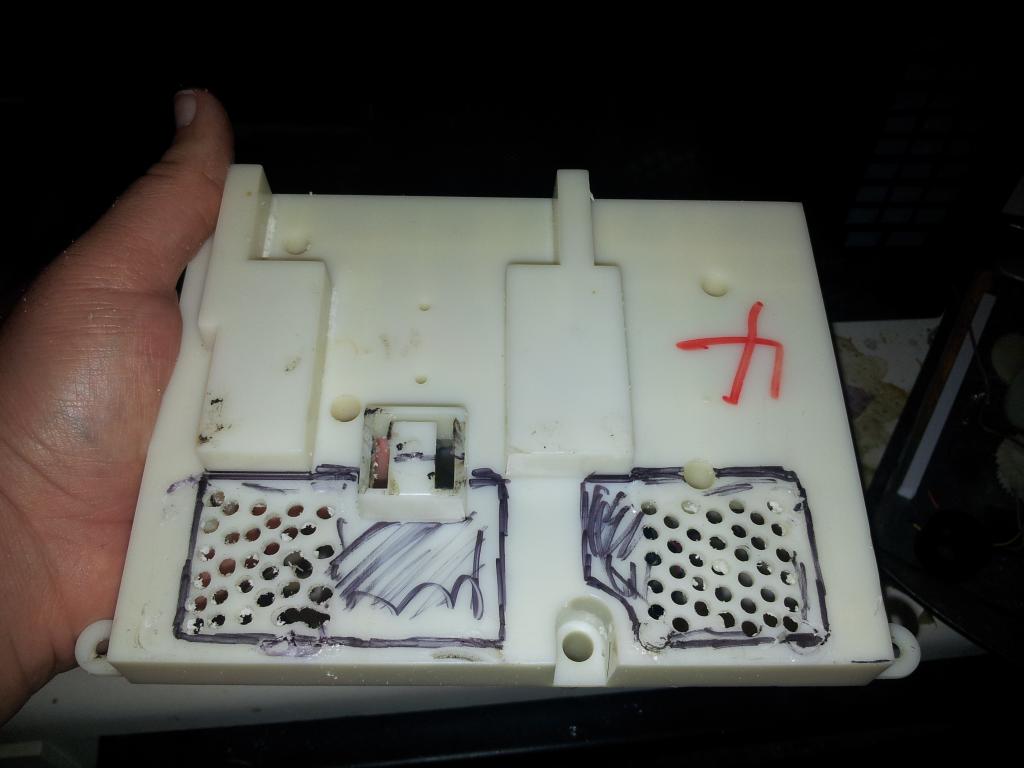
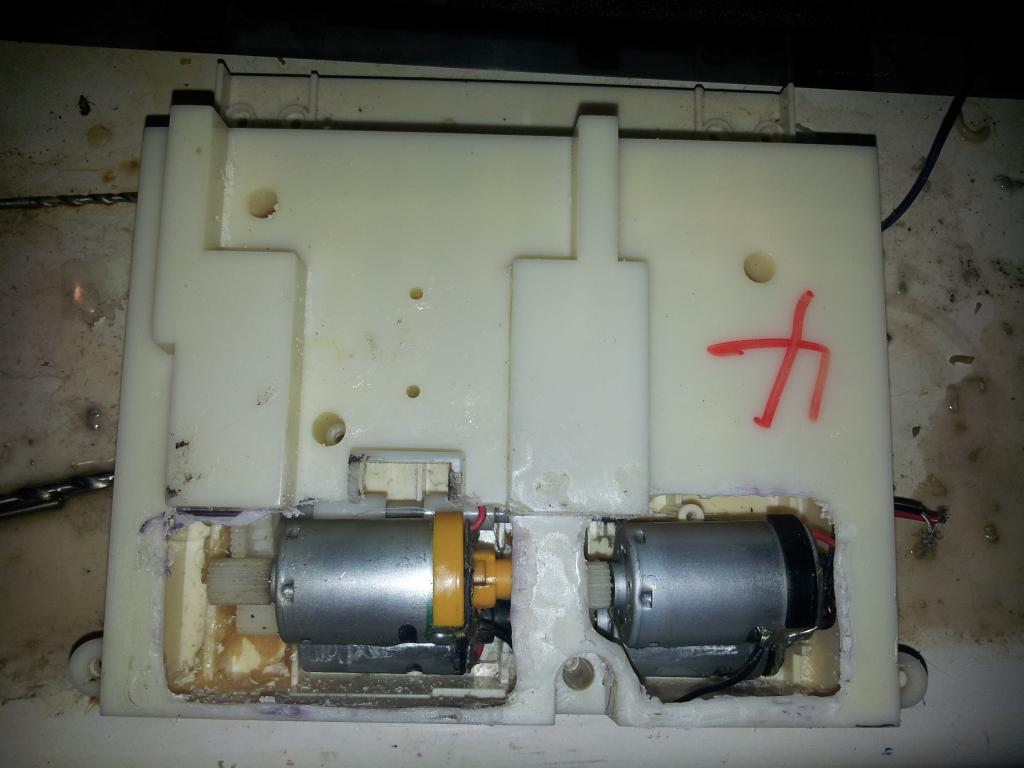
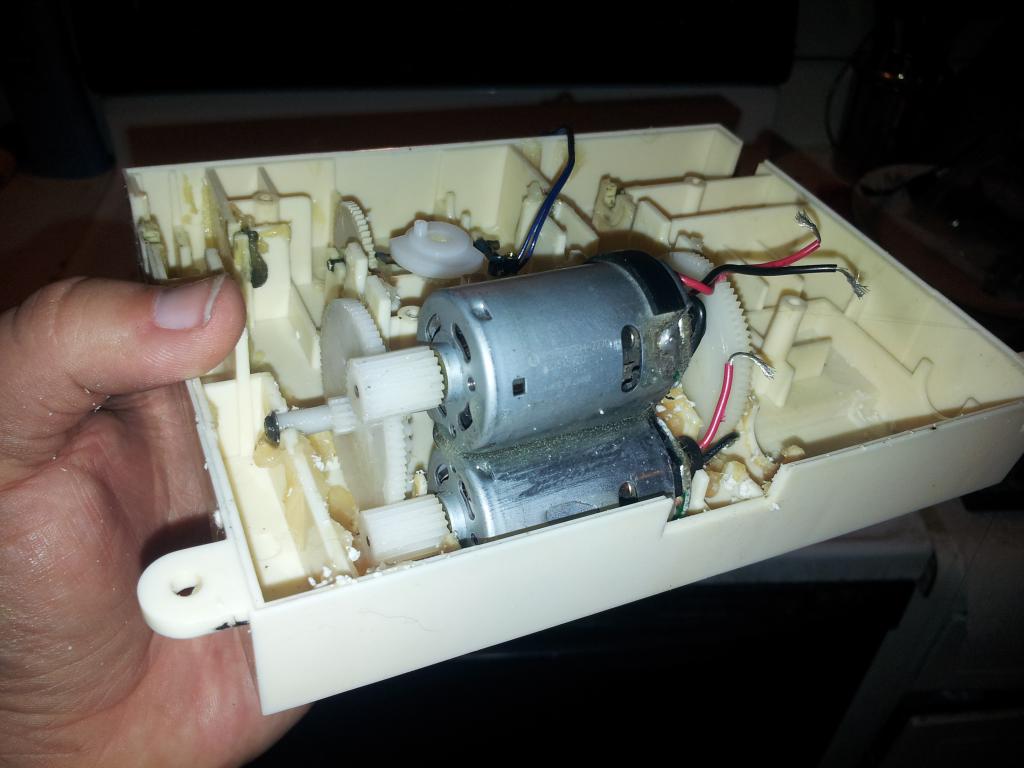
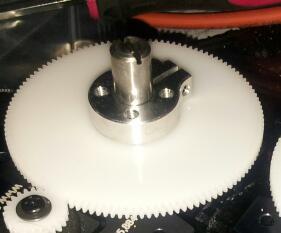
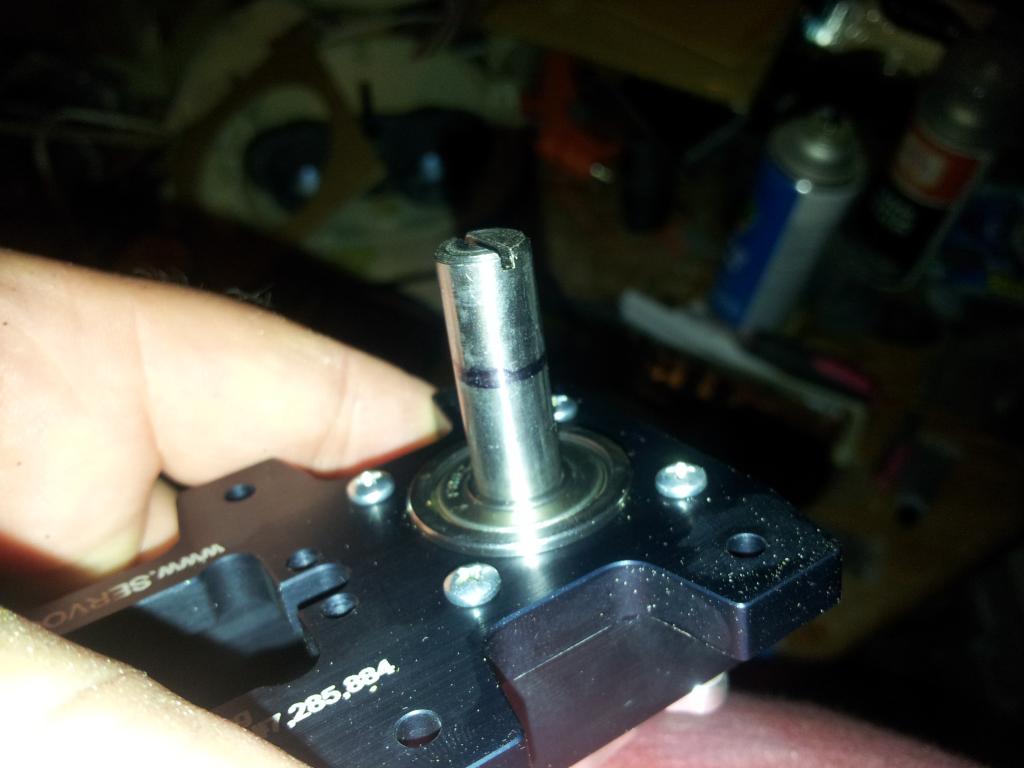
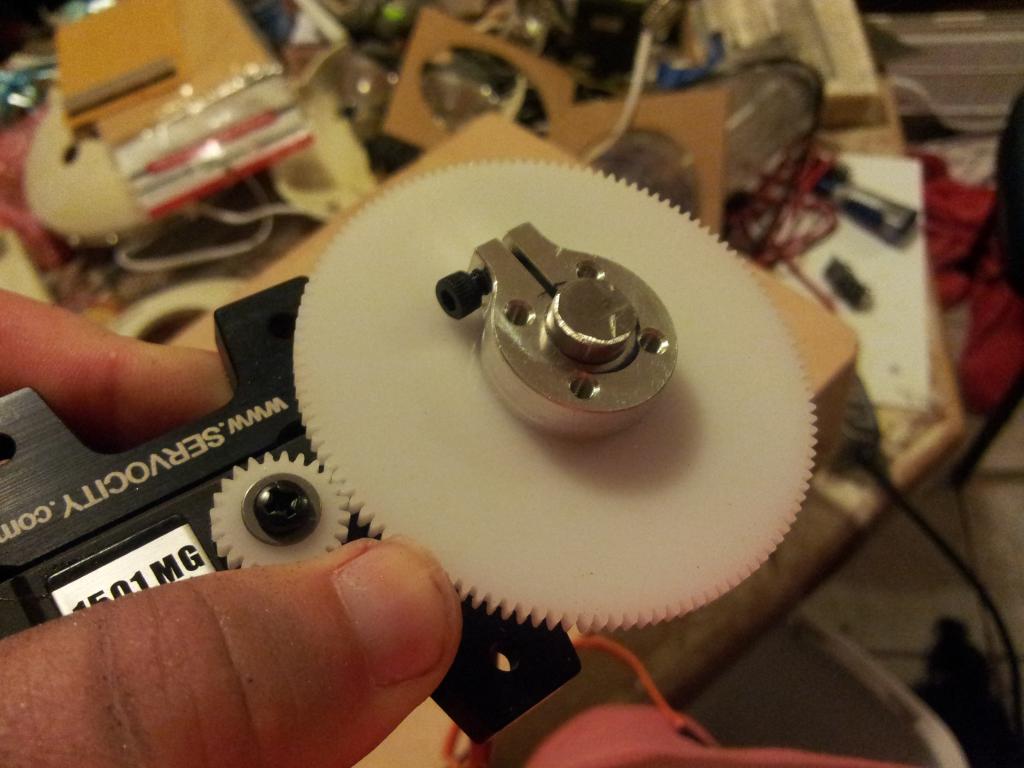
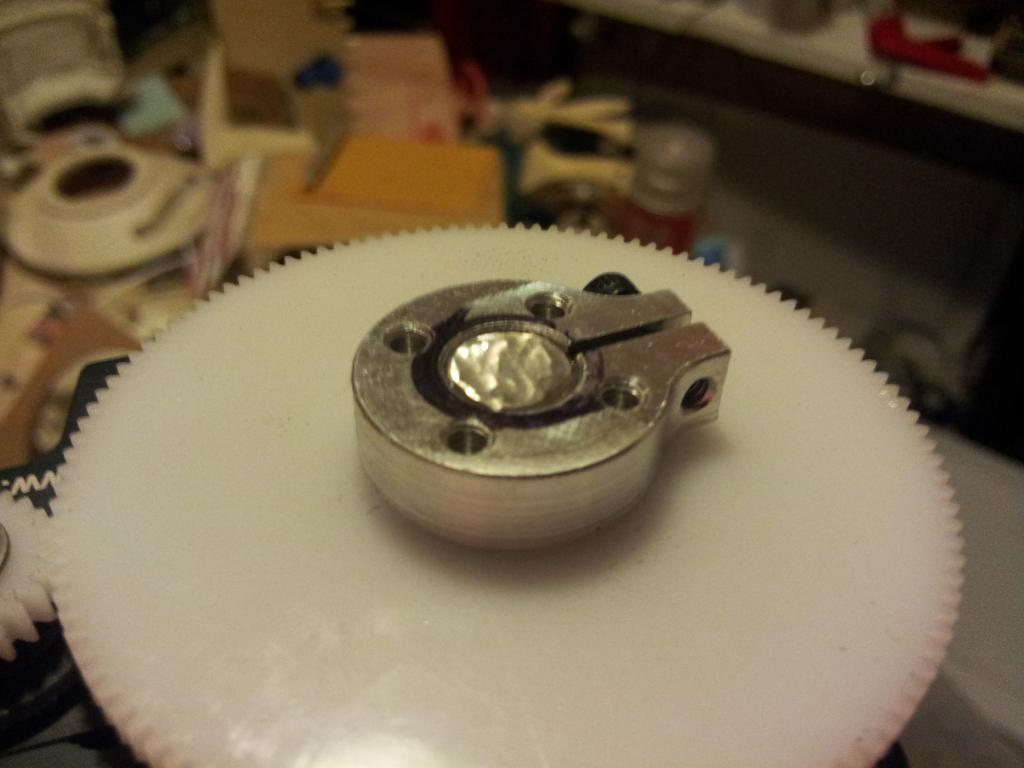
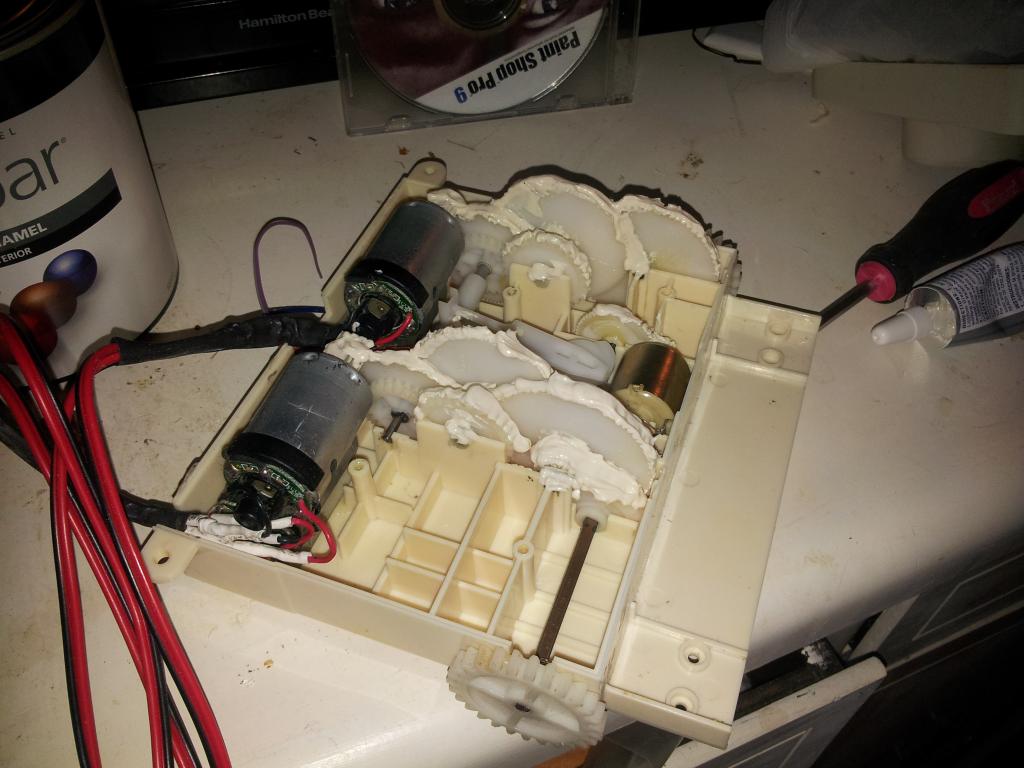
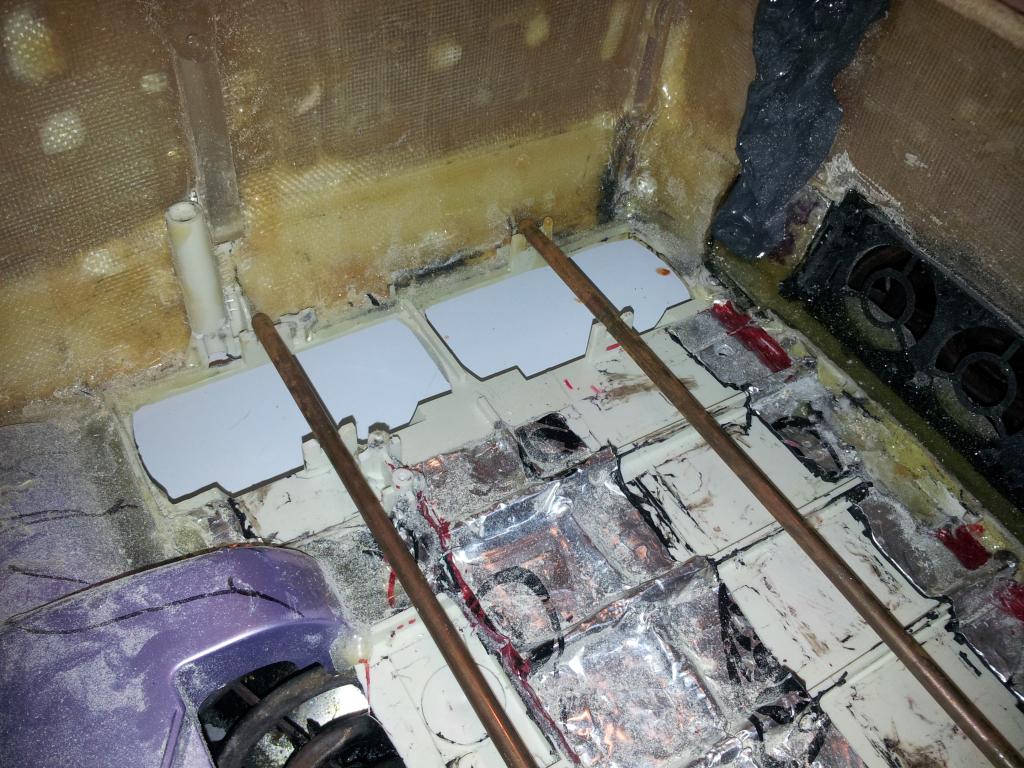
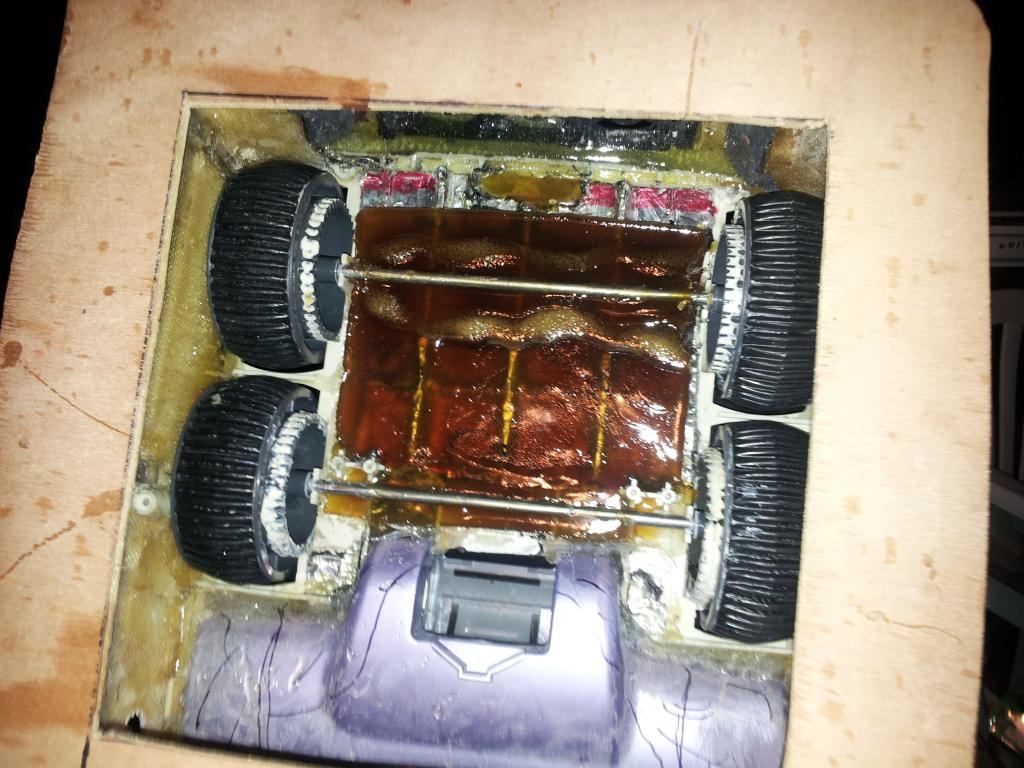
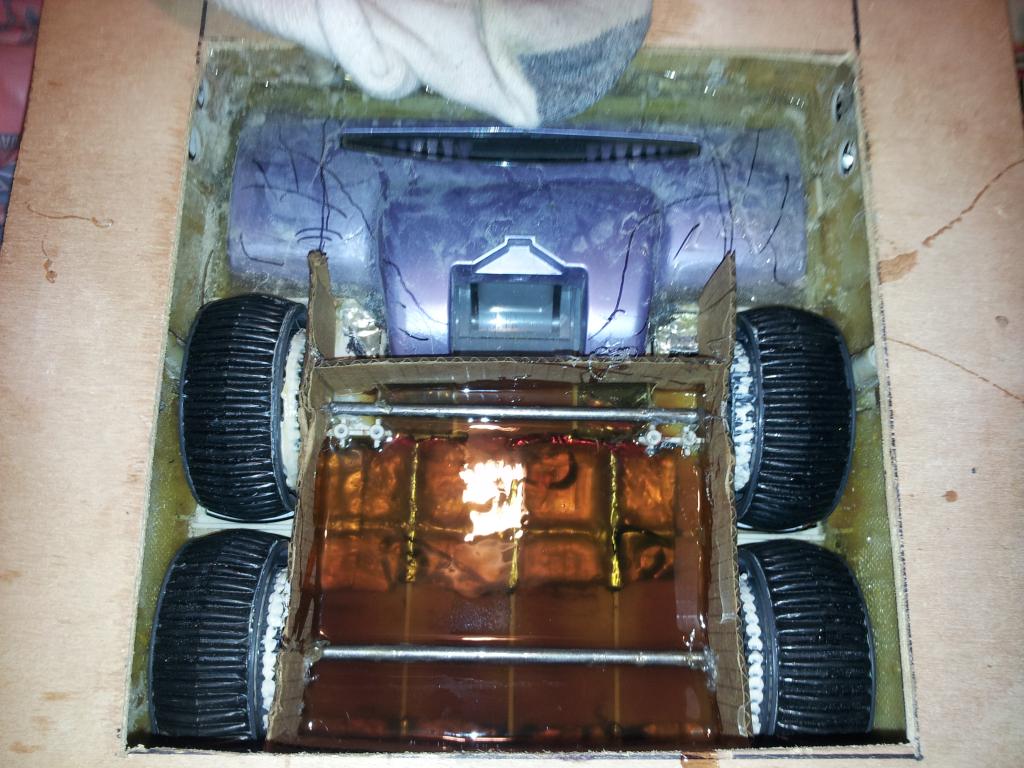
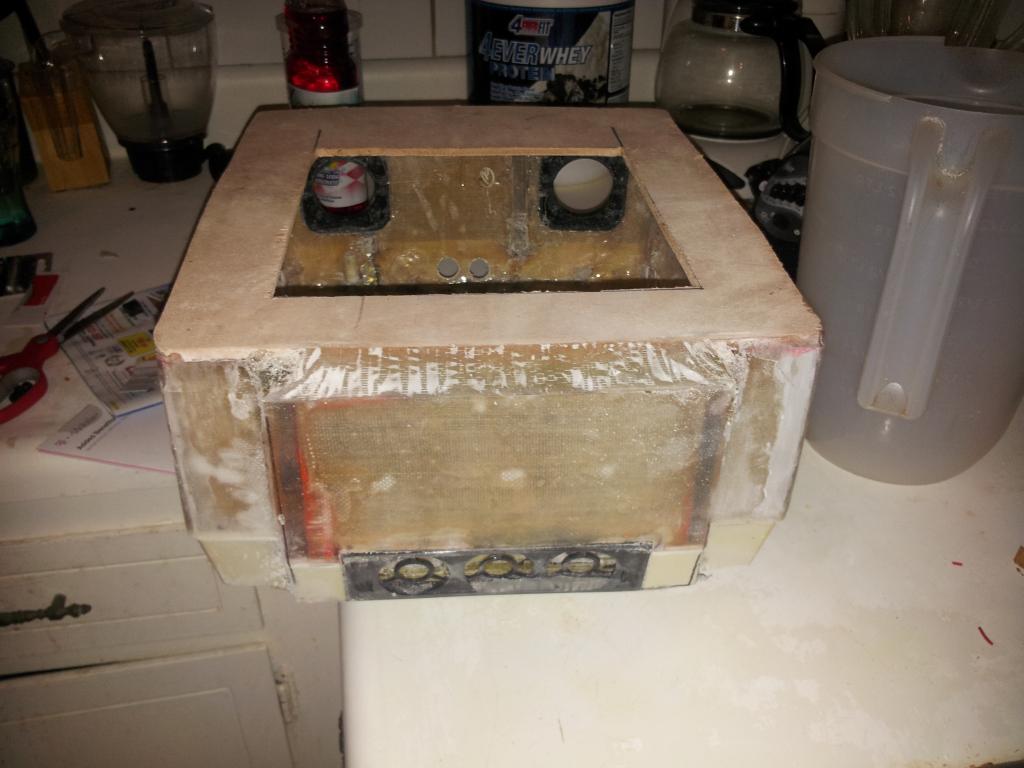
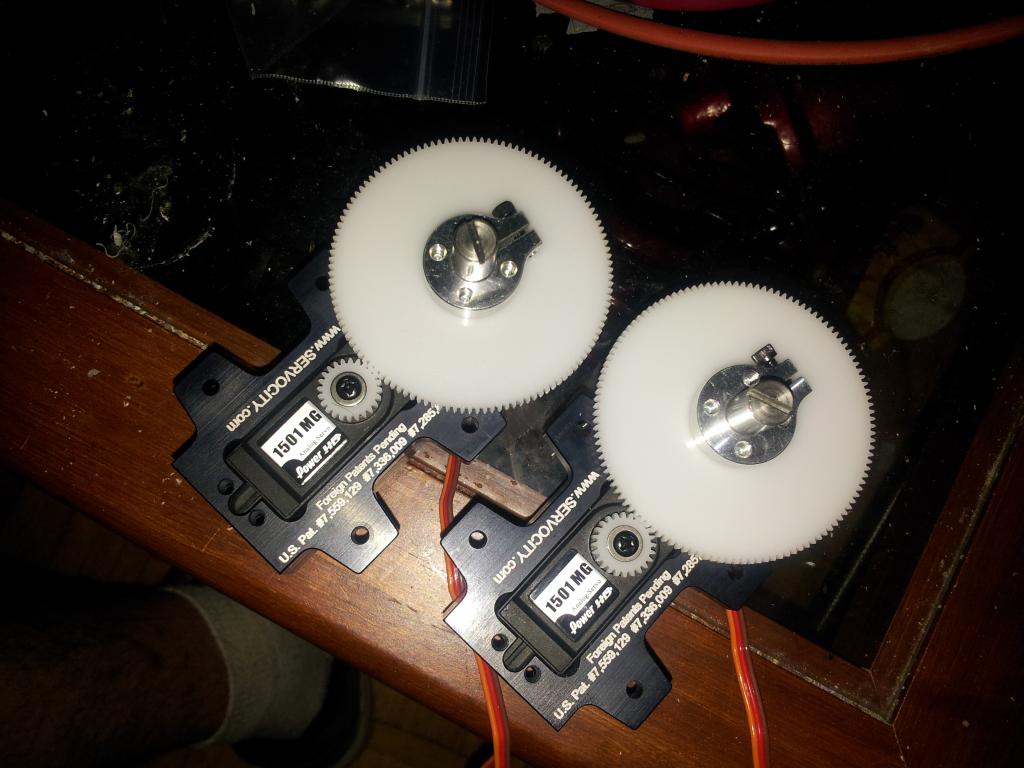
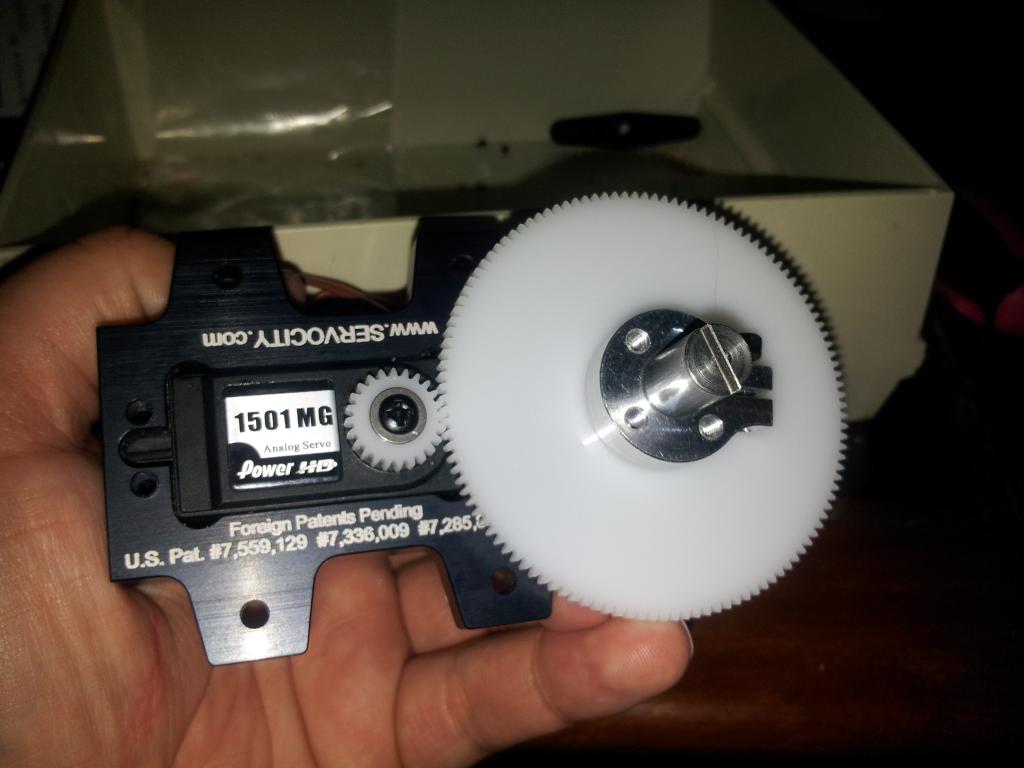
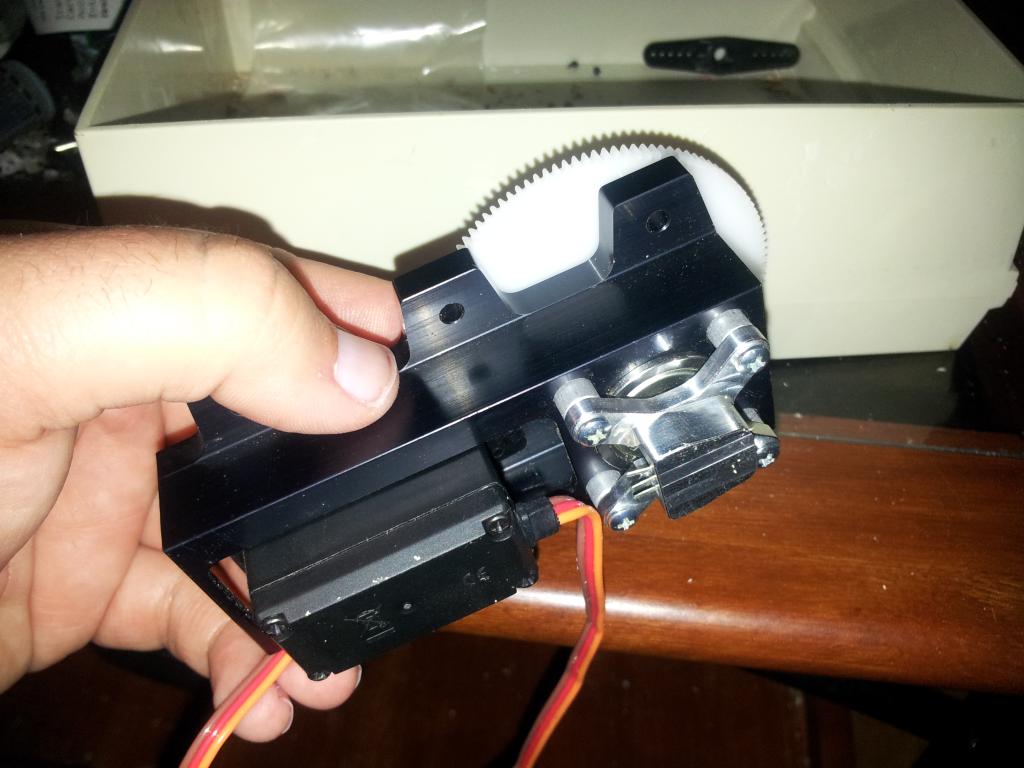
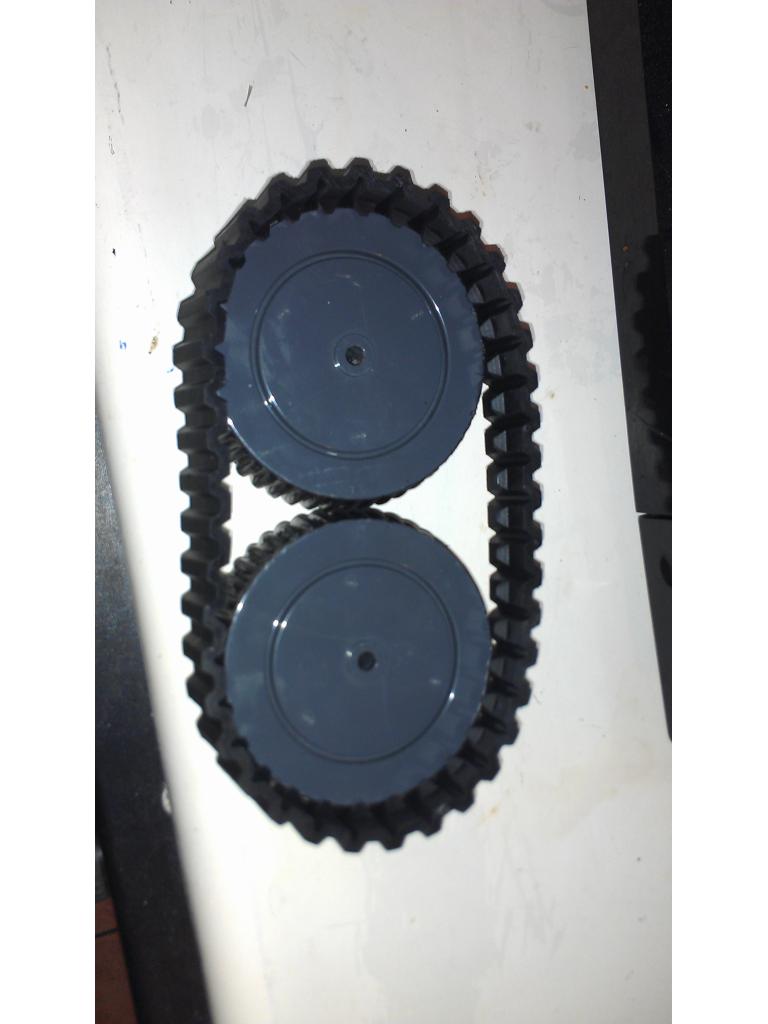
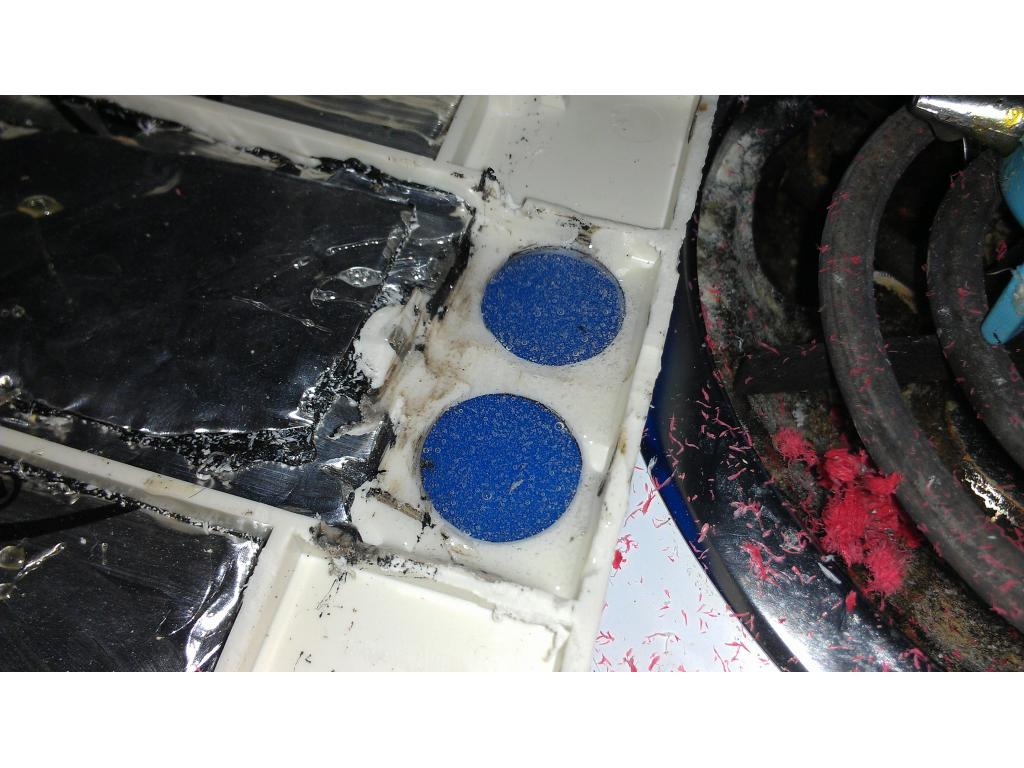
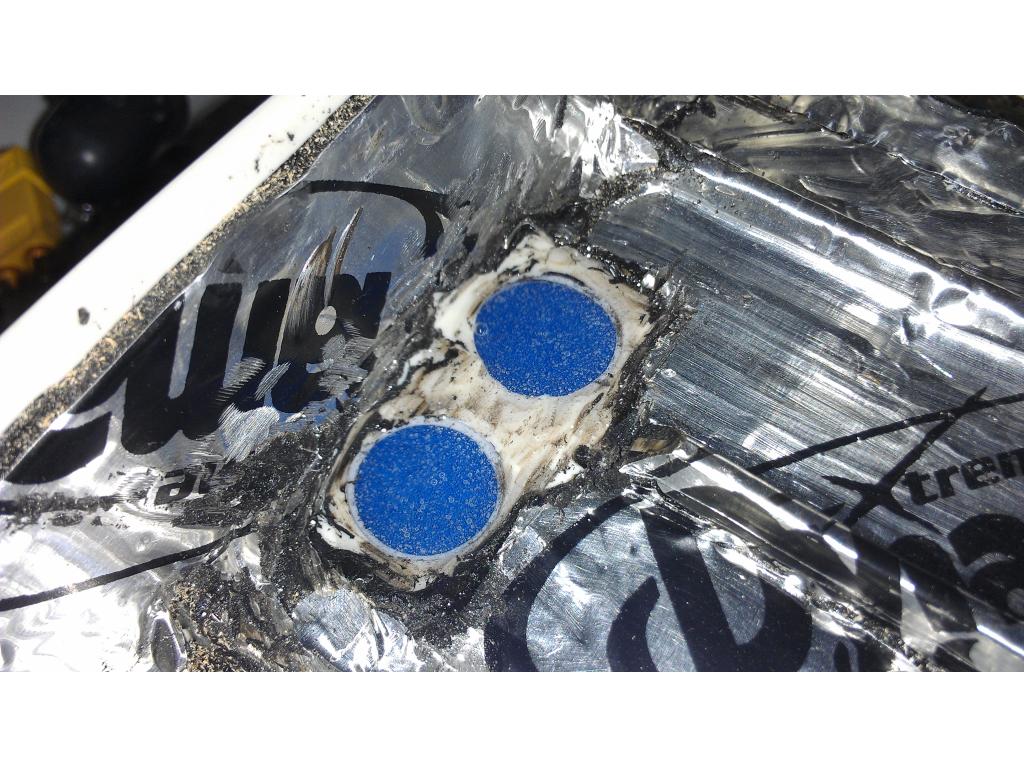
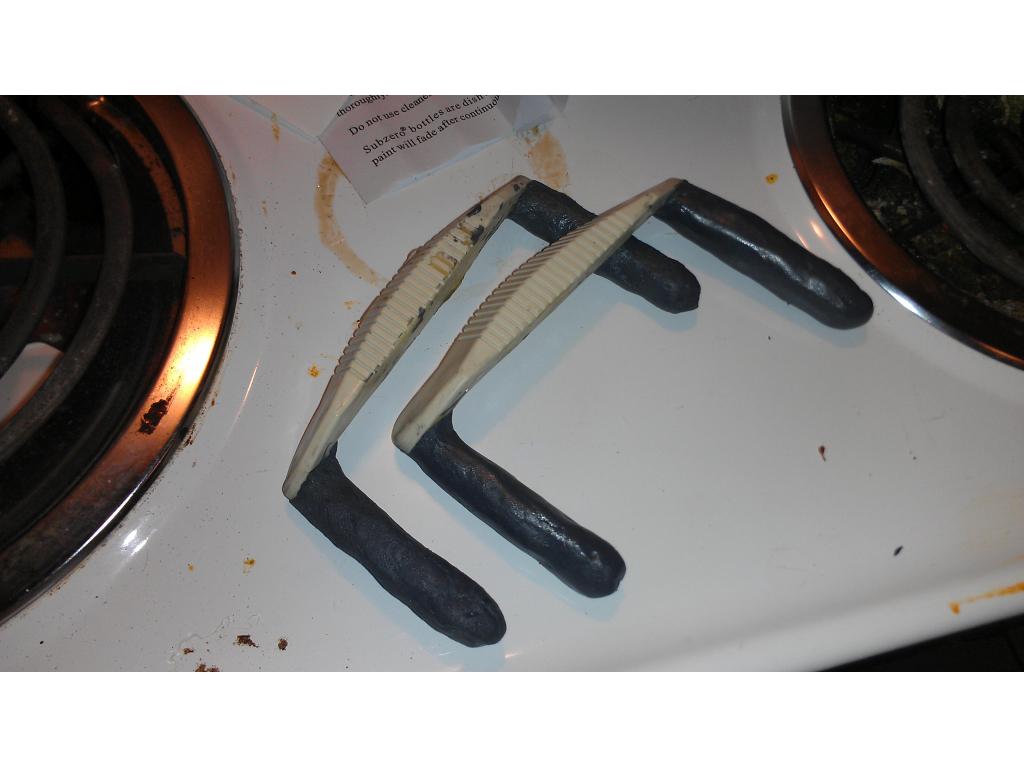
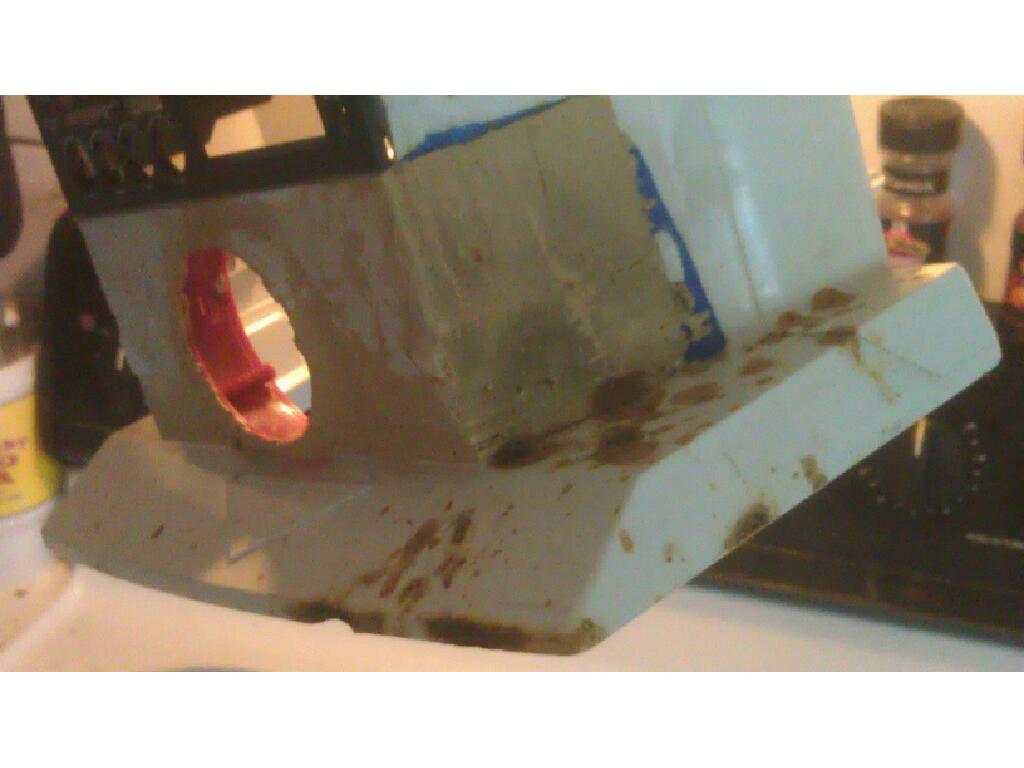
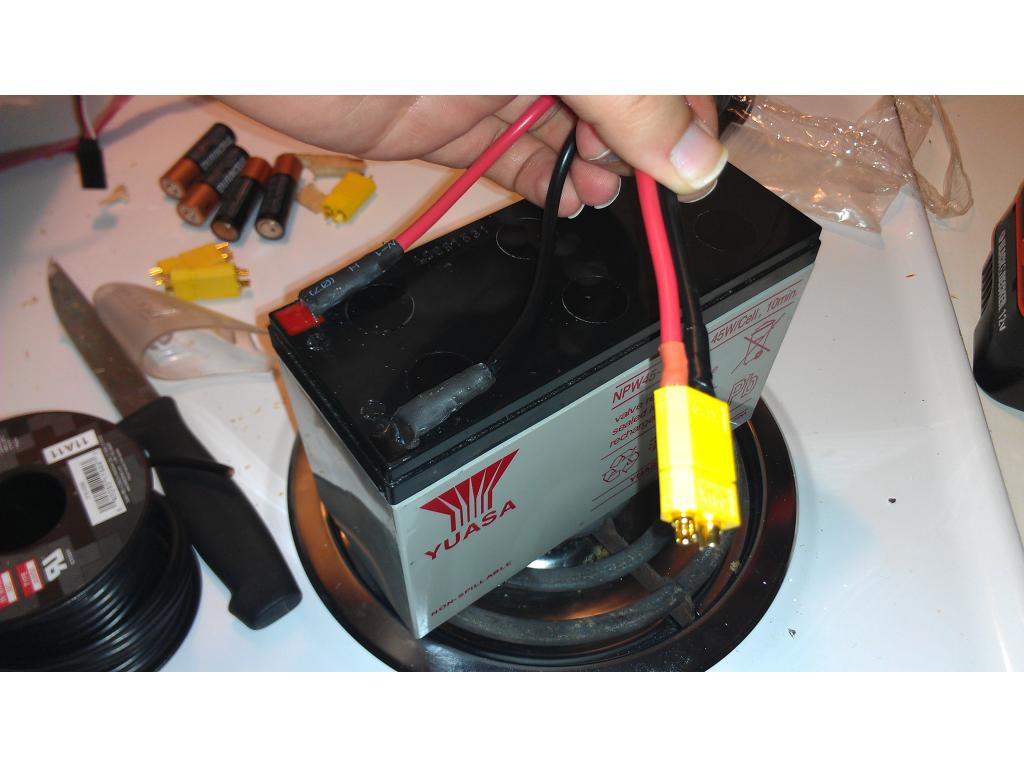
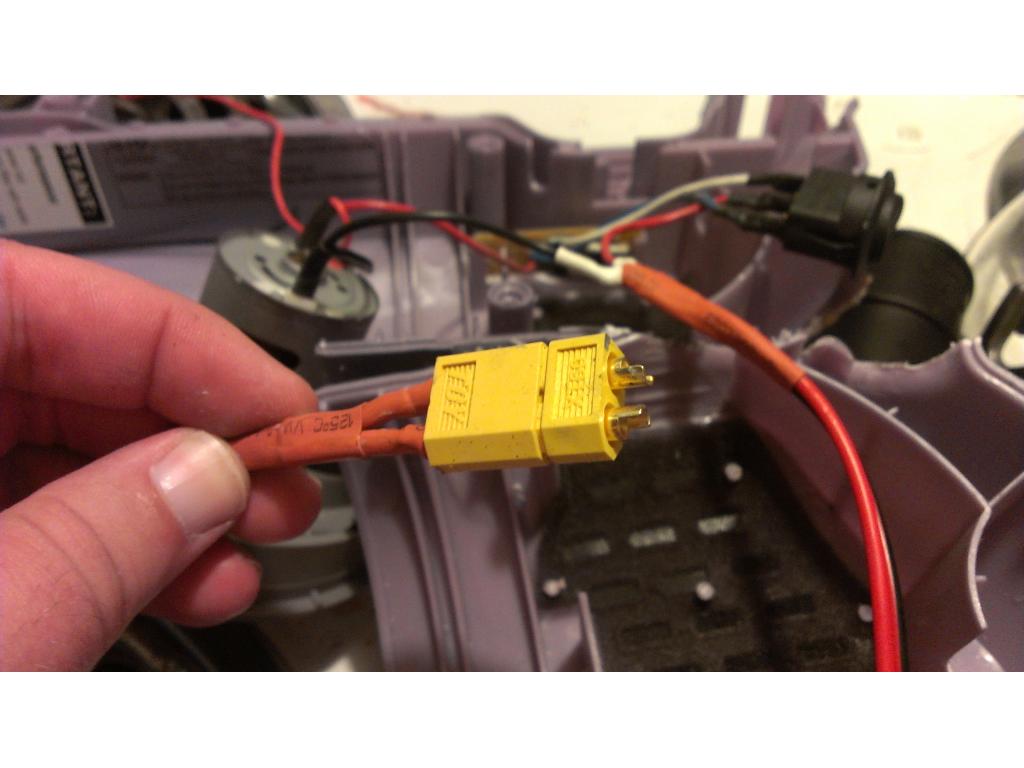
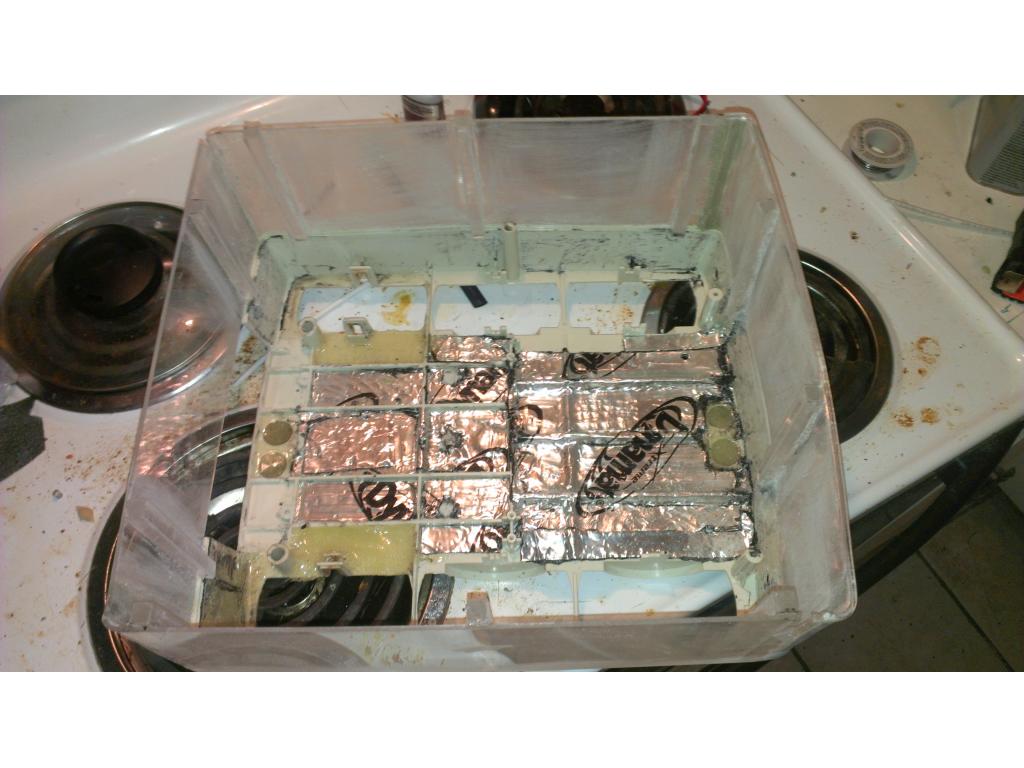
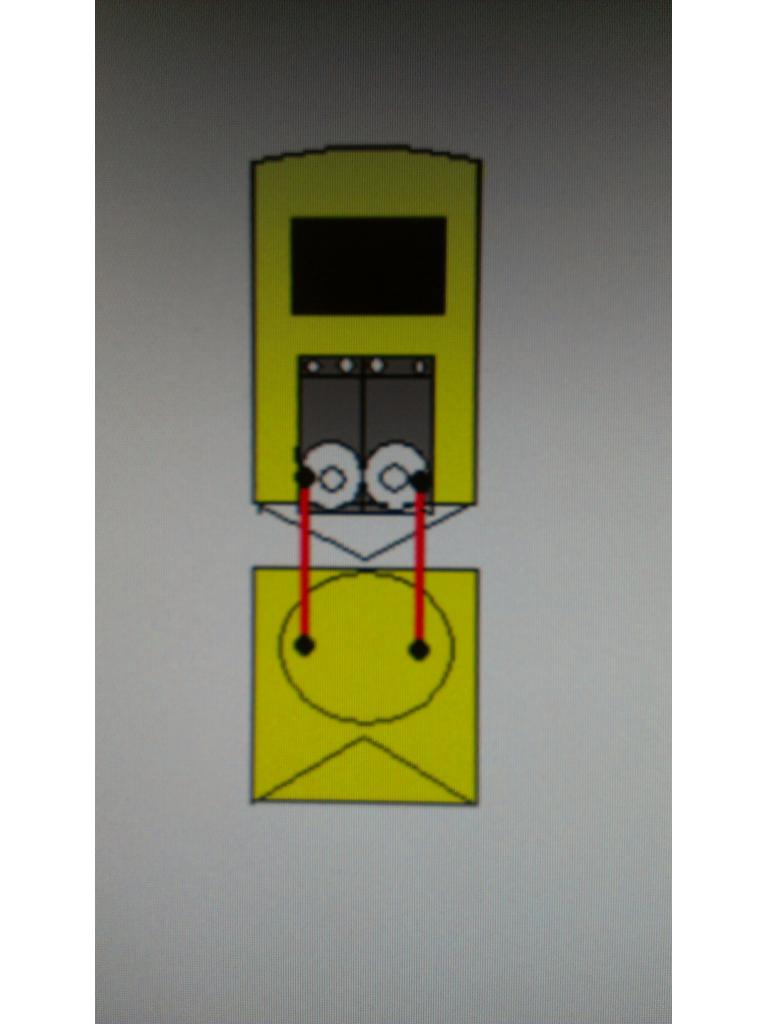
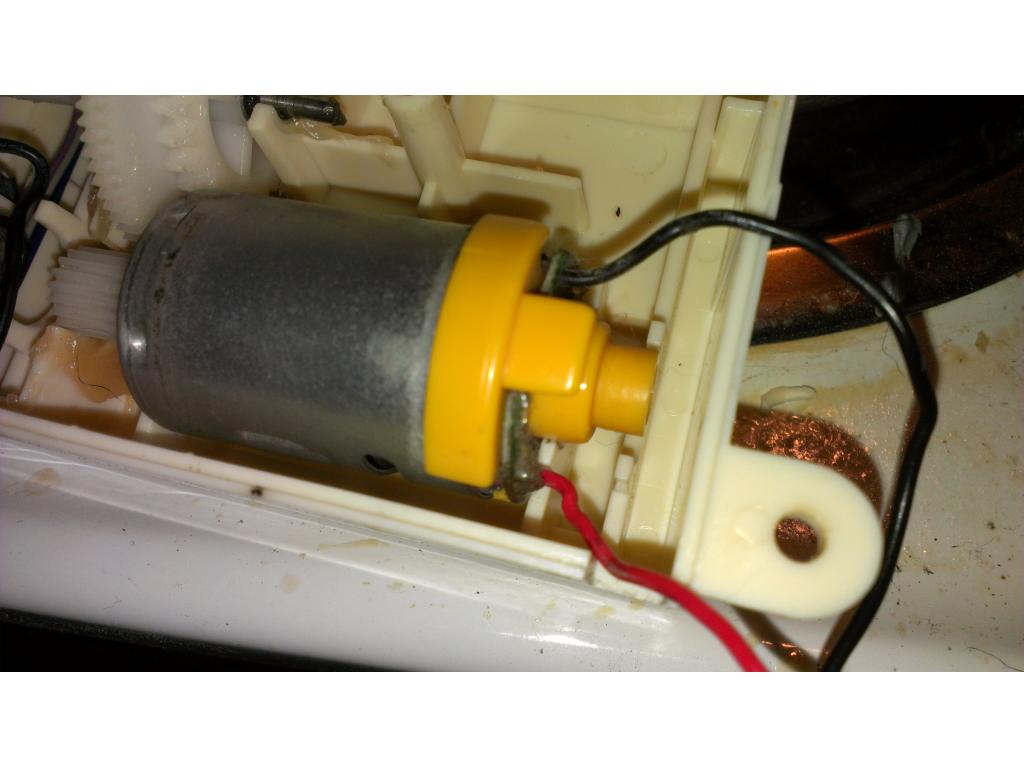
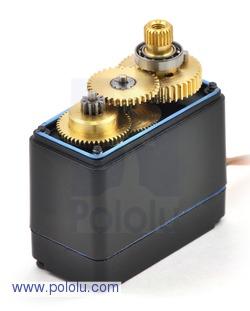
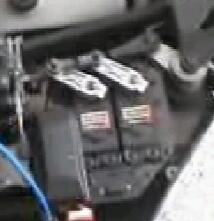
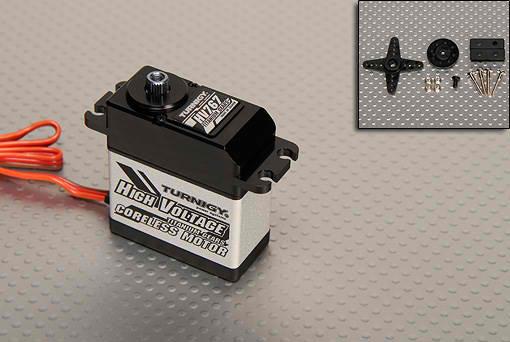
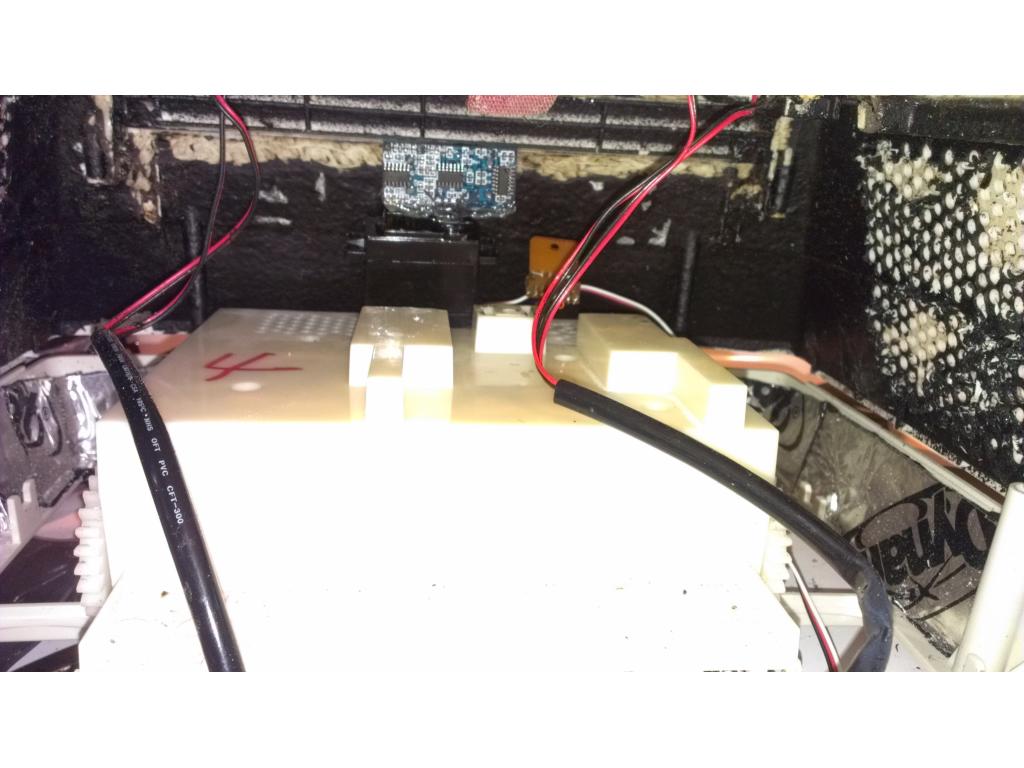
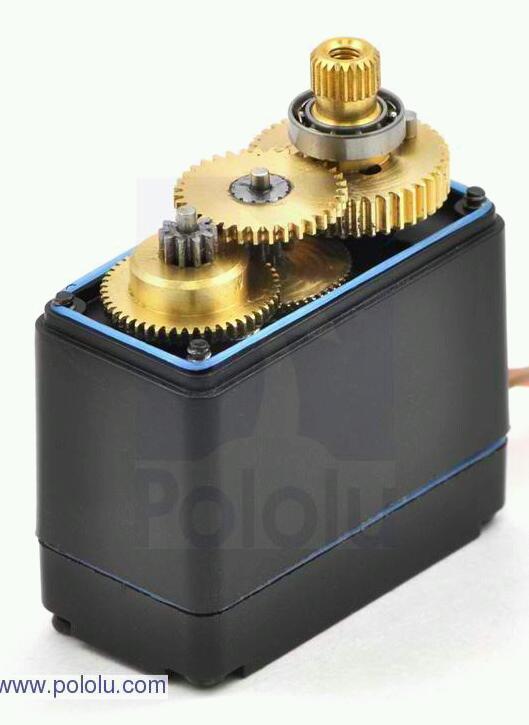
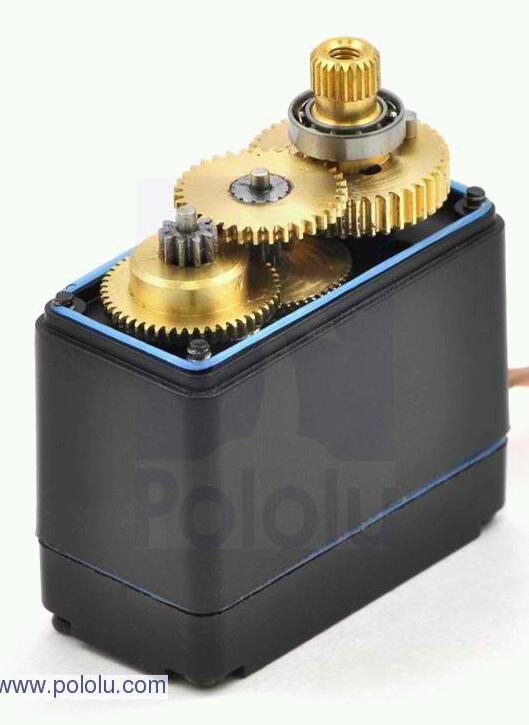
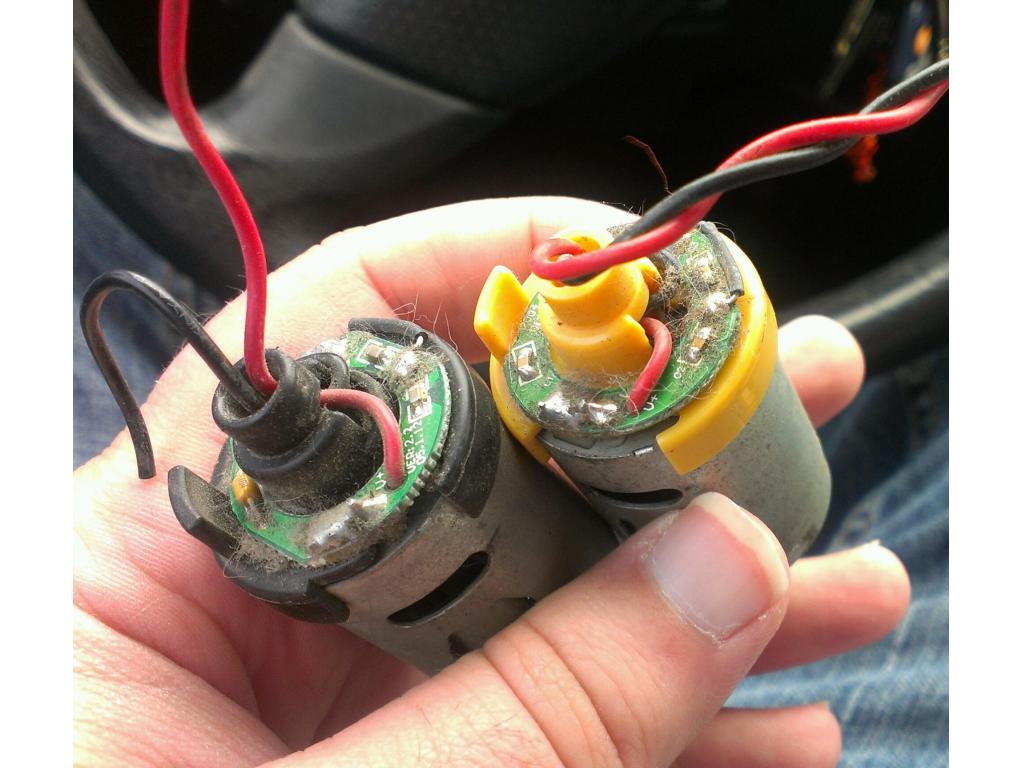
I soldered on power leads and covered the connections with heat shrink. Now I will probably just make a cover for the top to contain some noise and then I will cover it with a couple layers of dynamat.
SO FAR IT LOOKS GOOD AND CORRECT
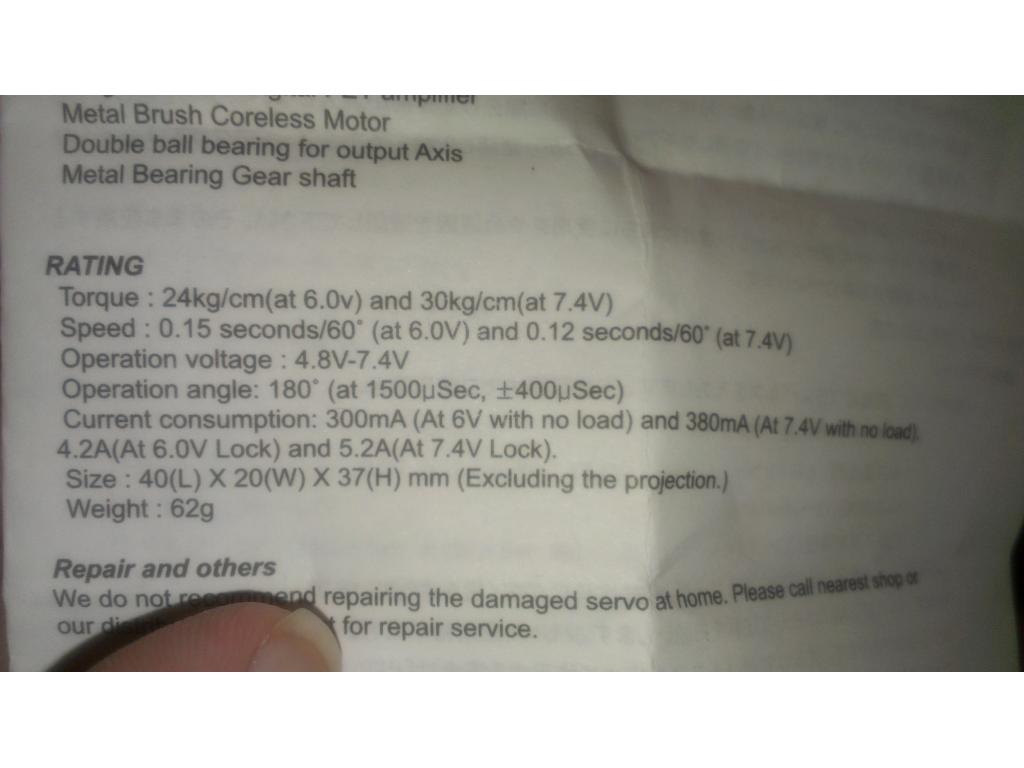
should handle 100 lbs or more,stall current will be very high so make shore your H-BRIDGE handles it
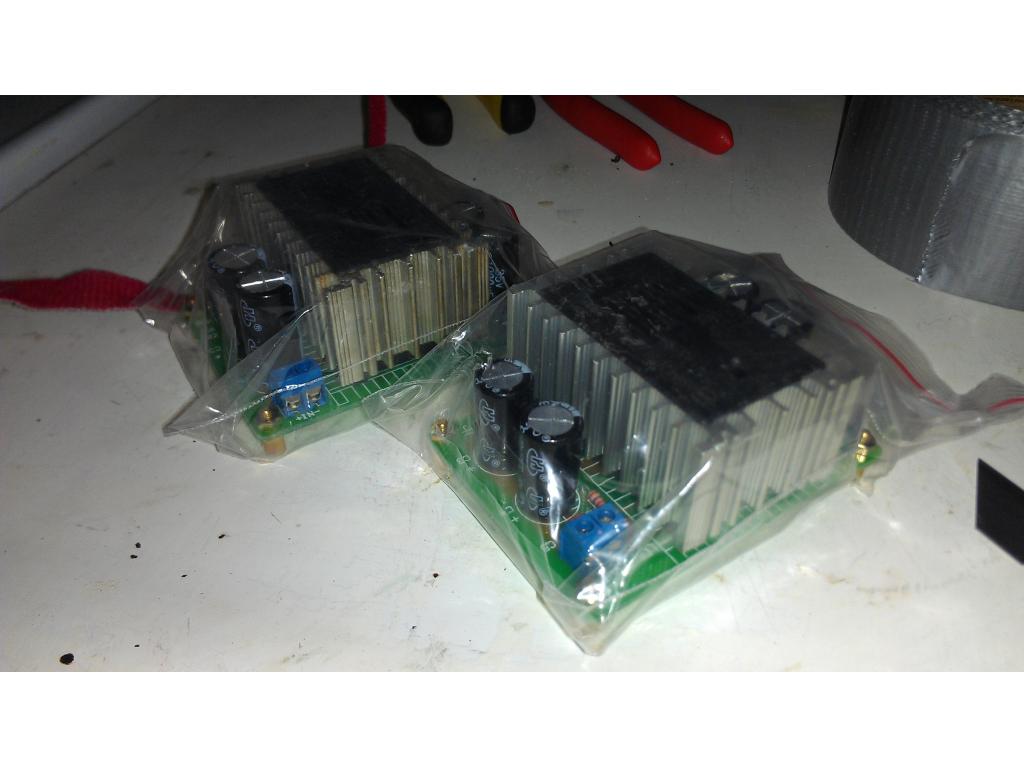
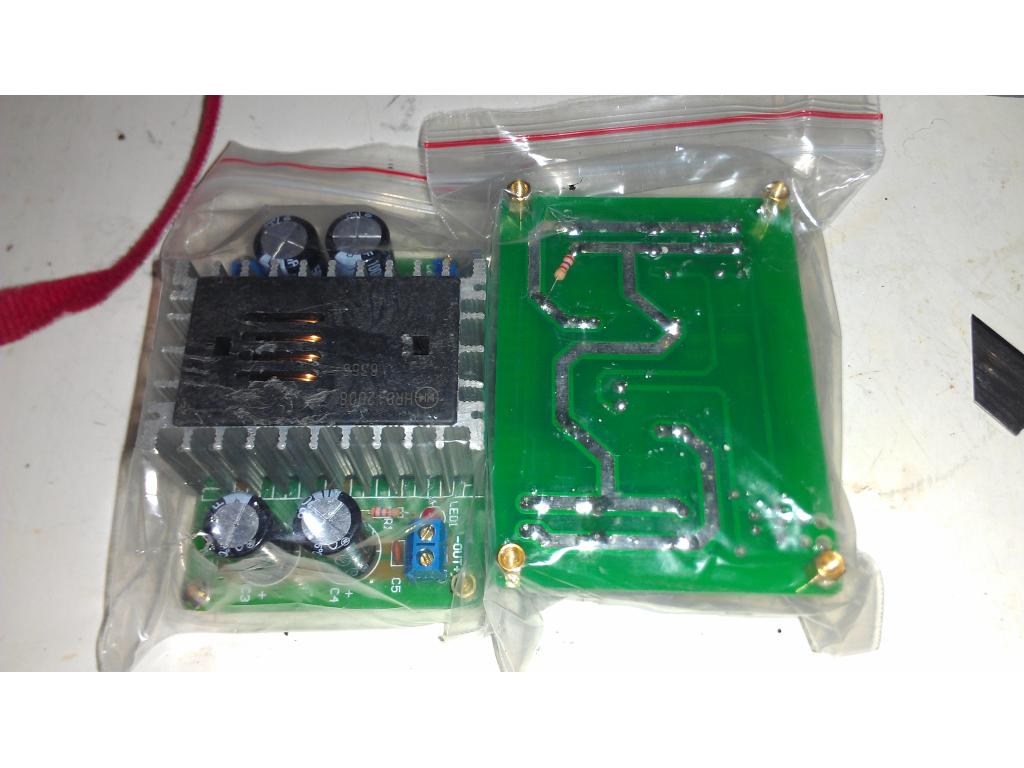
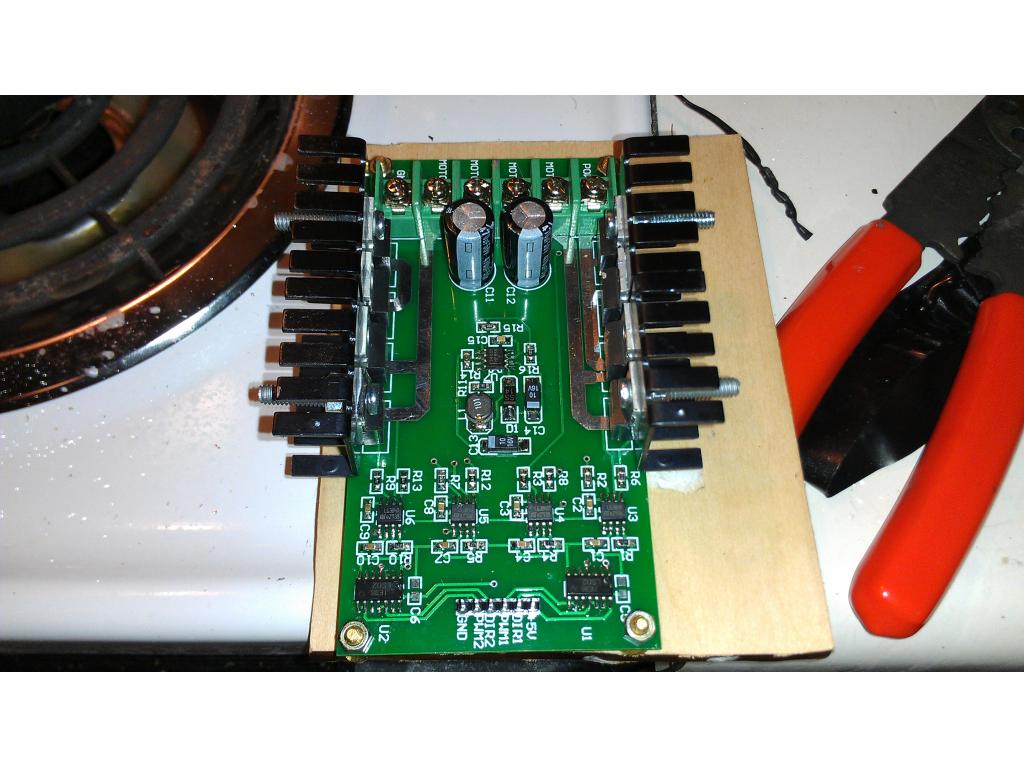
Thanks , I have l298 and a 10a hbridge .
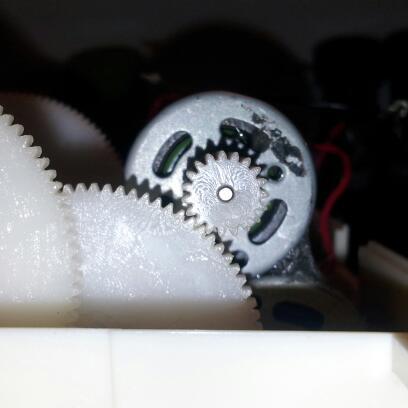
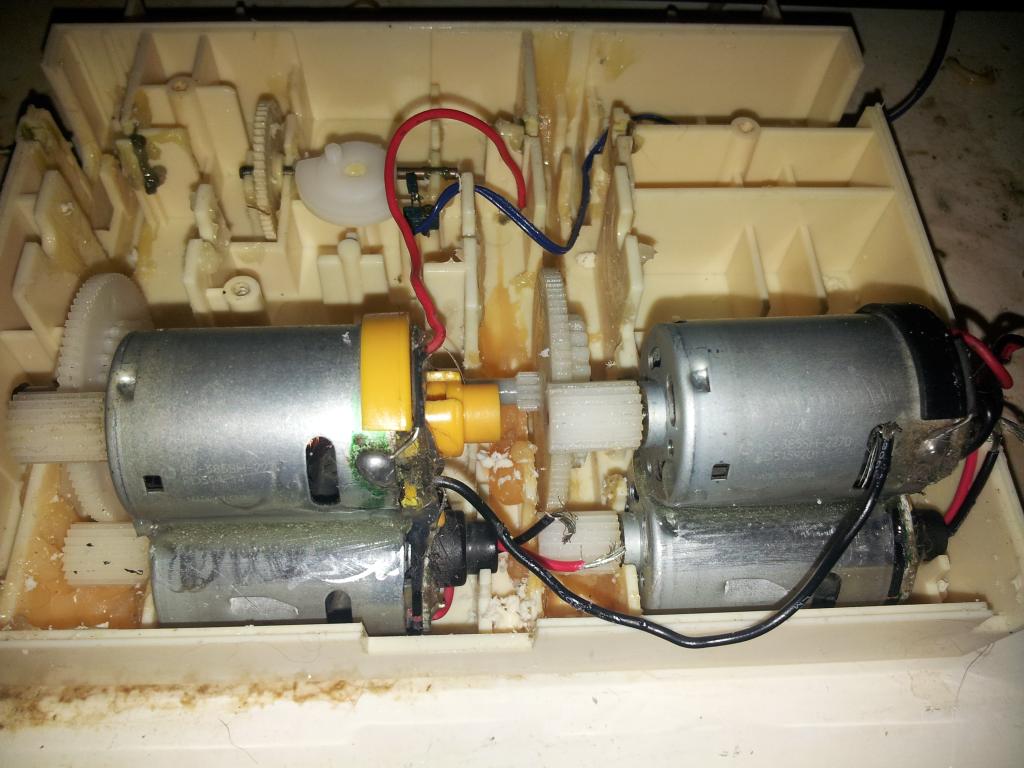
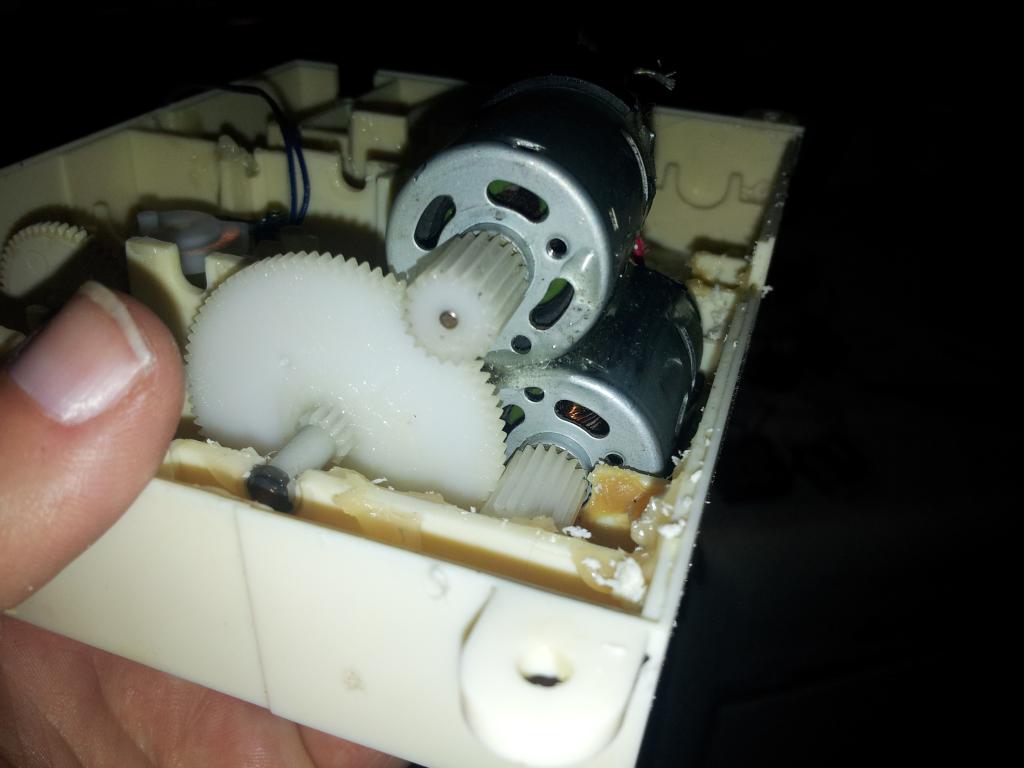
Nice work Josh! THat should move it around with ease. I like the way you paired them up - simple and effective.
i think it needs 1O AMP bridge,since using only one motor per side on the roomba it takes 5 amp modification to the roomba circuit design i am working on and you are using 2 motors per side
Looks like a perfect fit.
Nailed it!
Thankyou everyone! This was a all nighters mod.
@Robotmaker I think that's the first time you straight up said I did a mod right! Lol
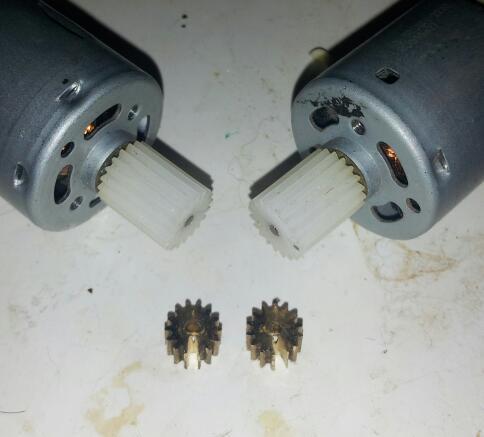
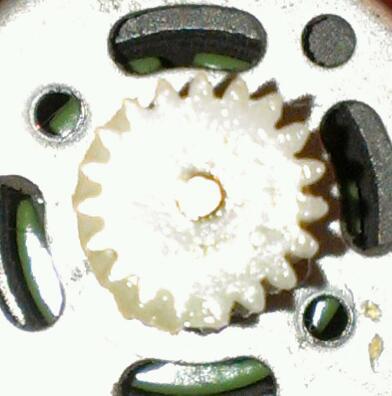
@Troy thanks for the set of pinions
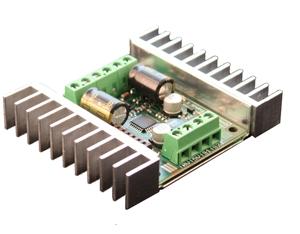
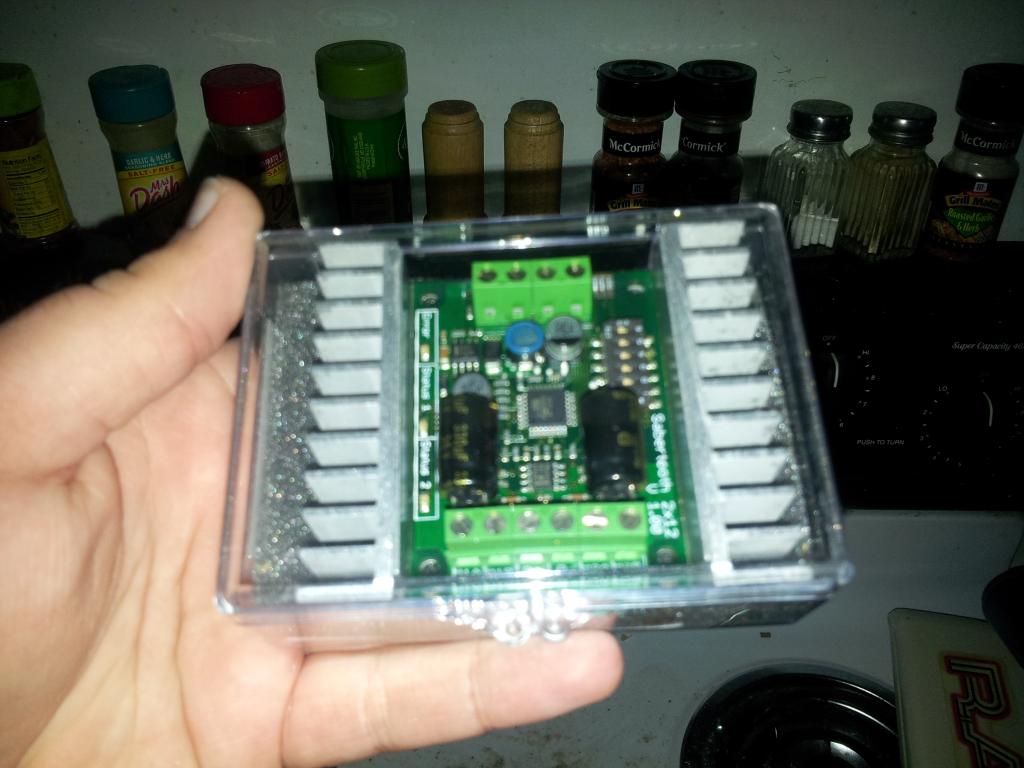
So I have that 10a controller but Brett had problems getting it to run. As always IM looking for simple yet effective. Should I just go buy a sabertooth controller and call it a day? Input please I want to order something today.