


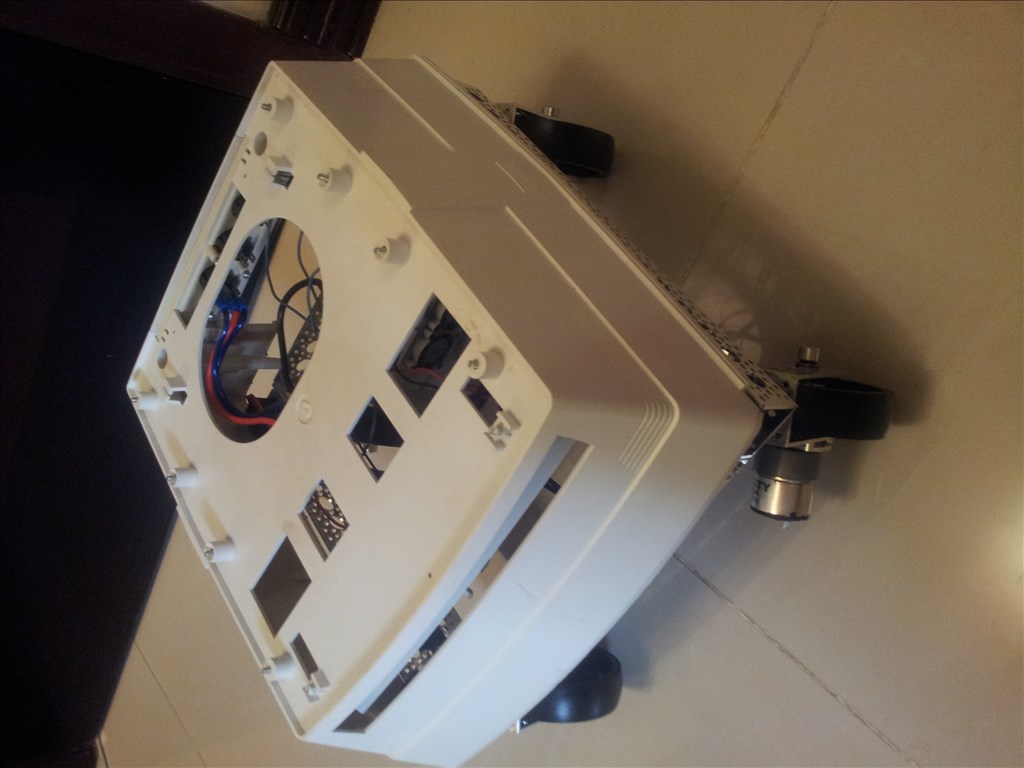
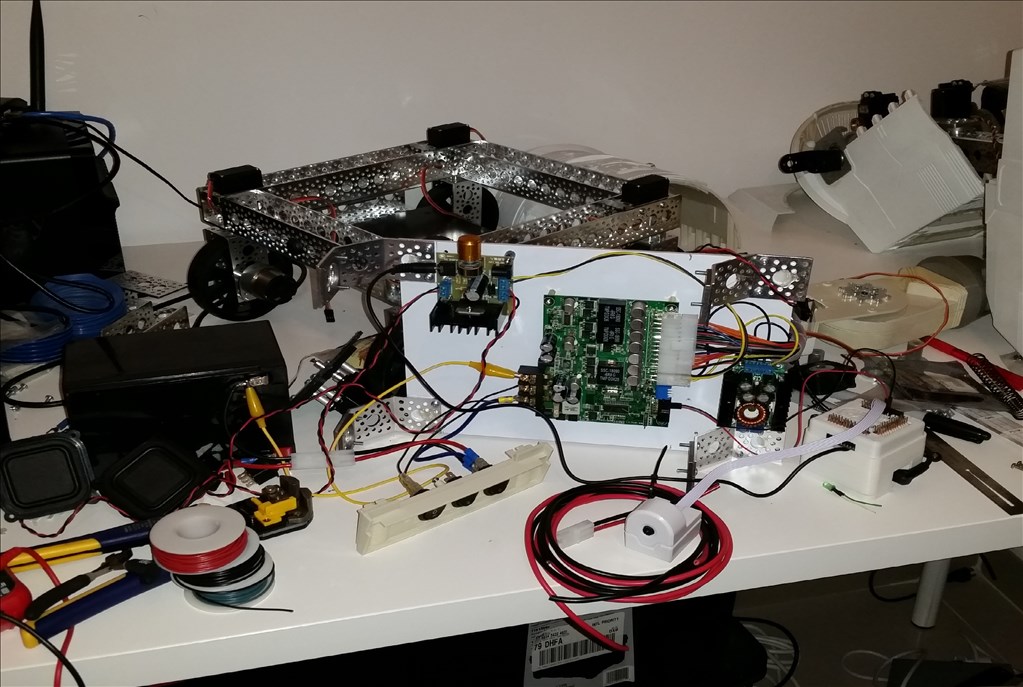
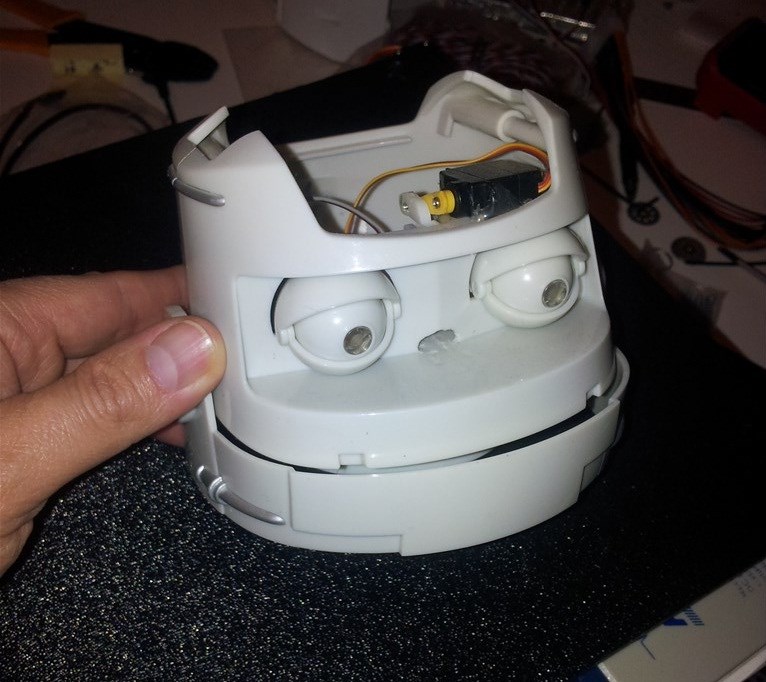
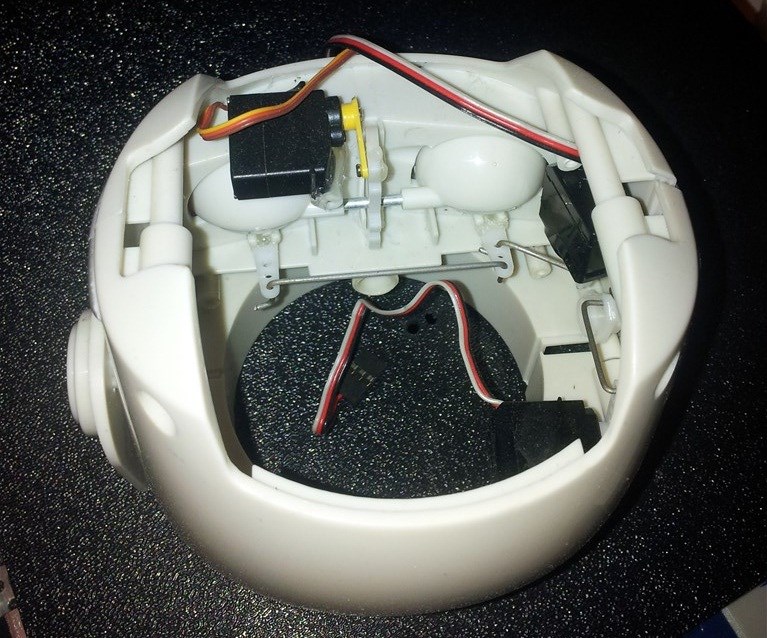
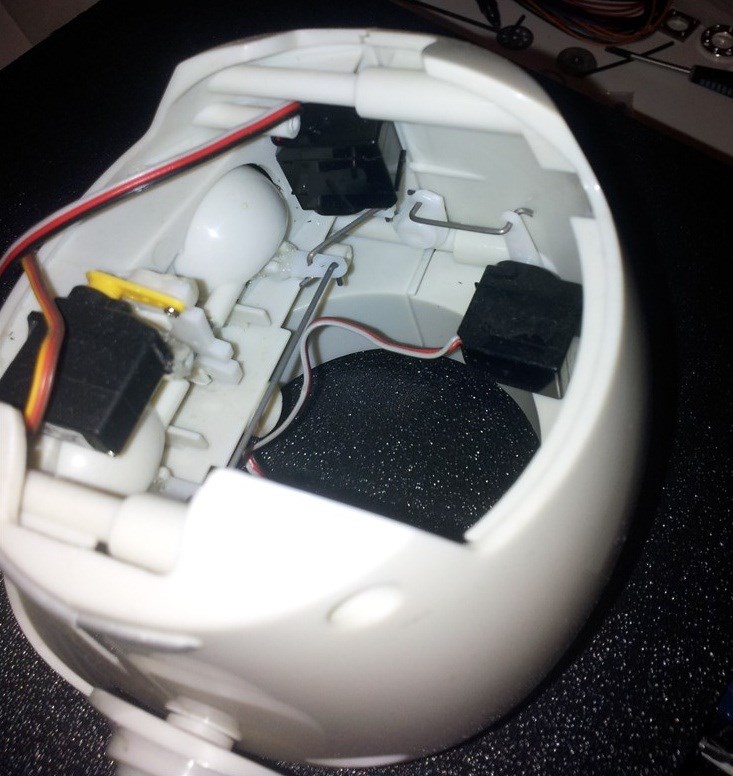
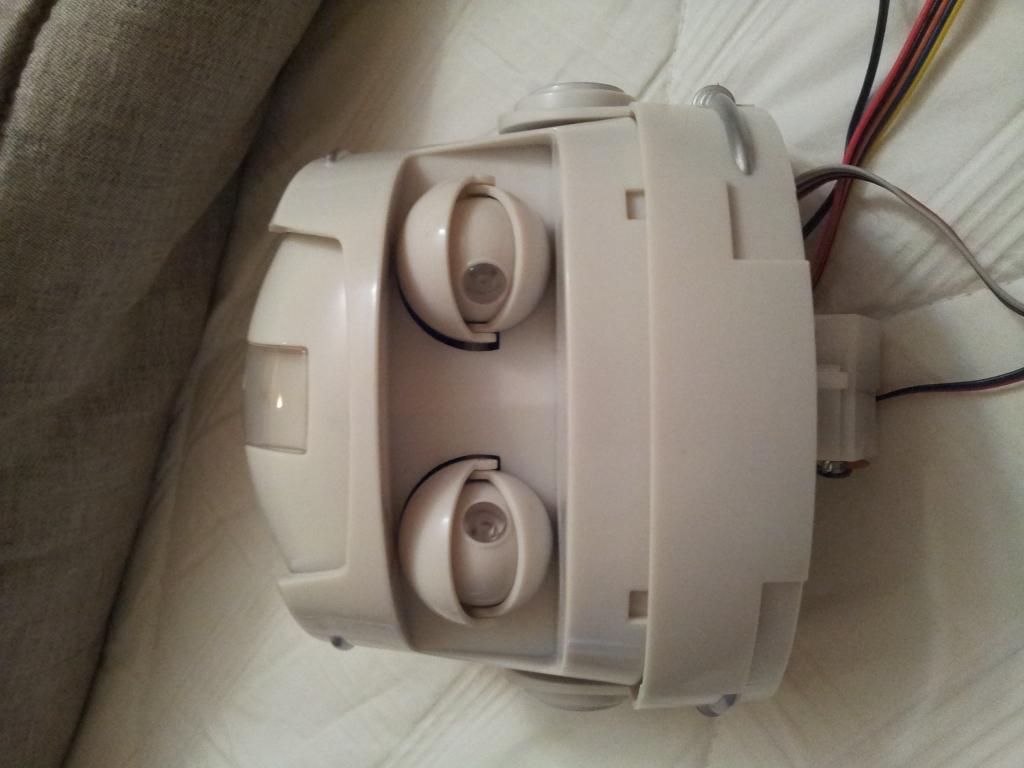
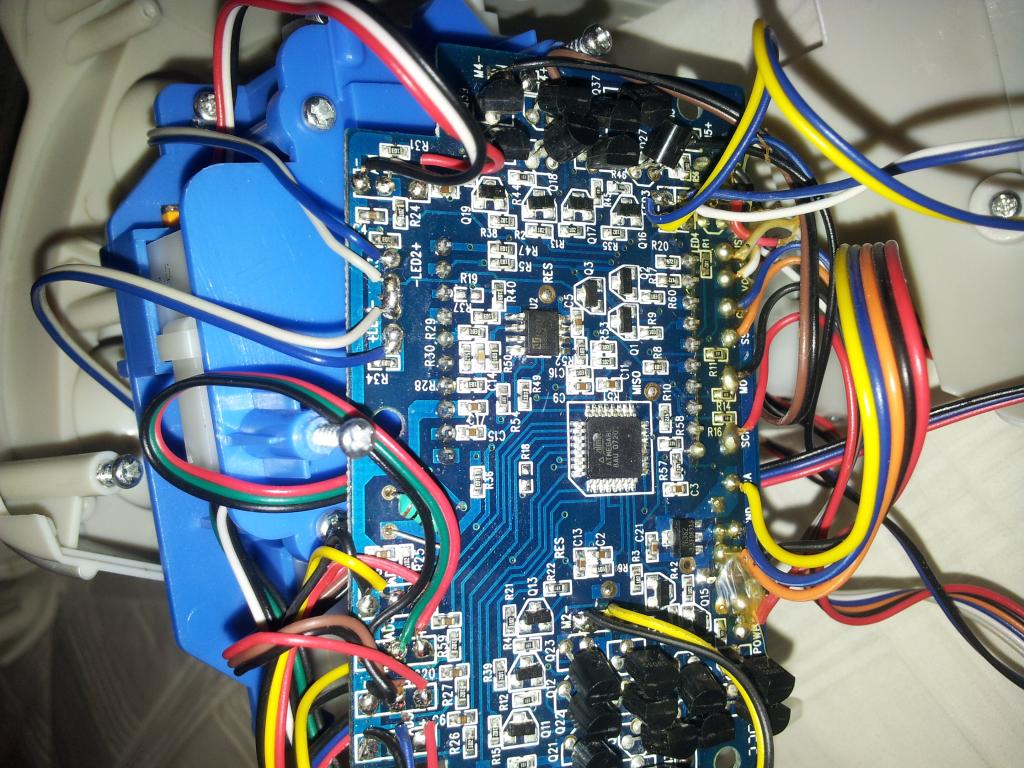
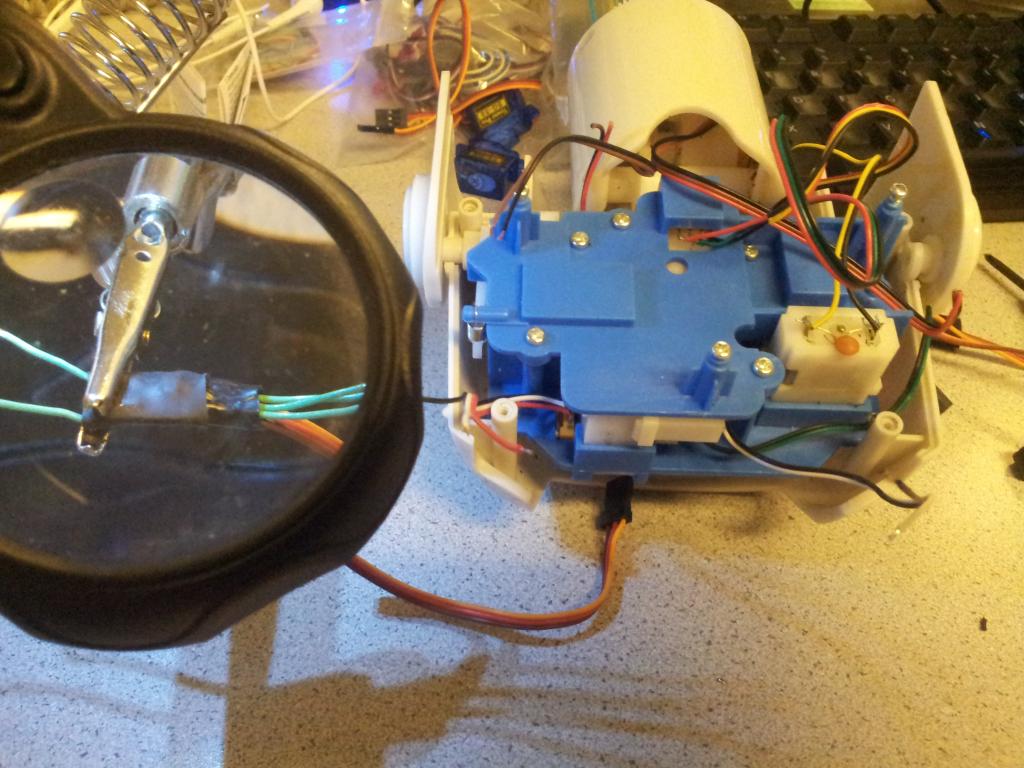
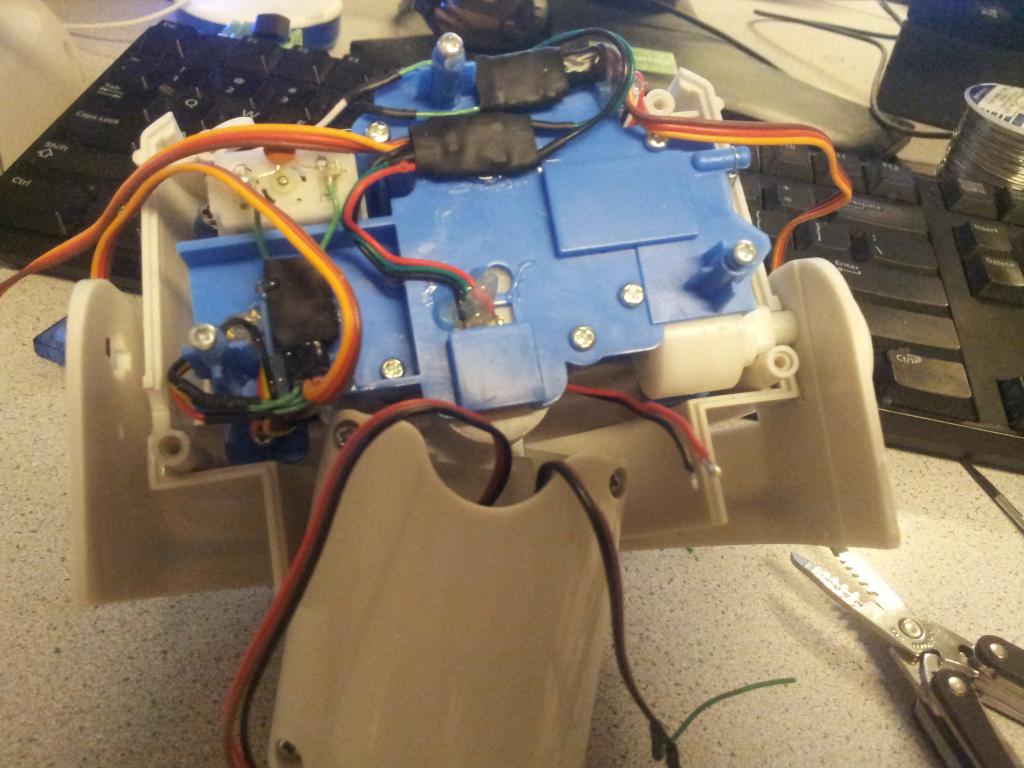
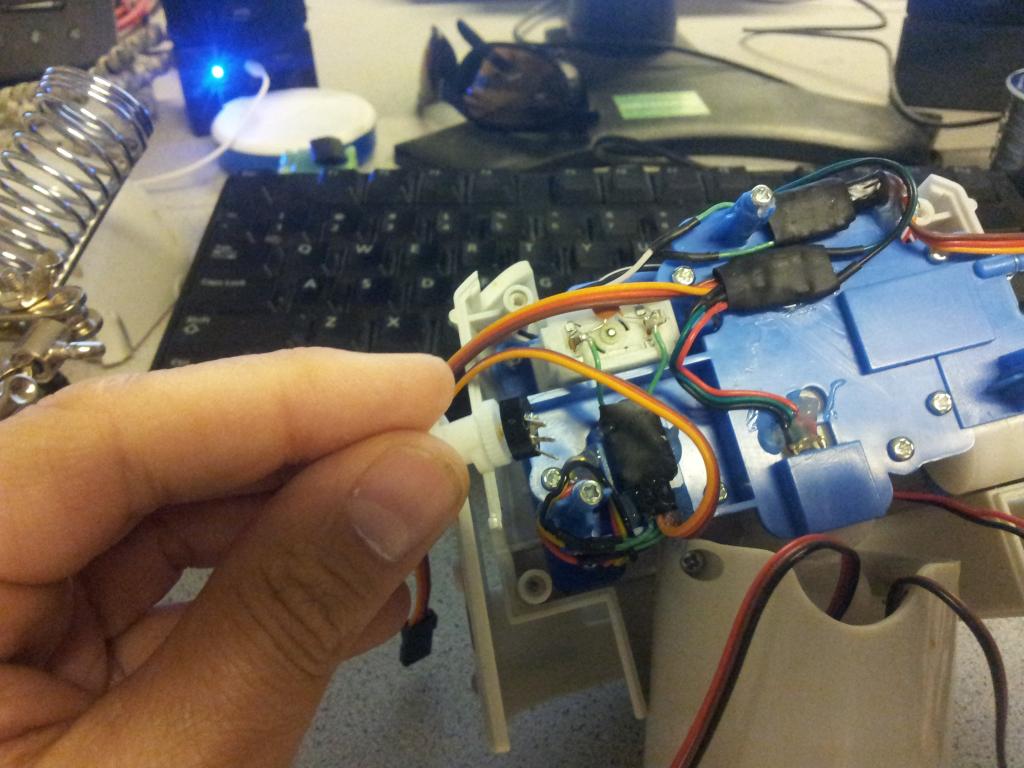
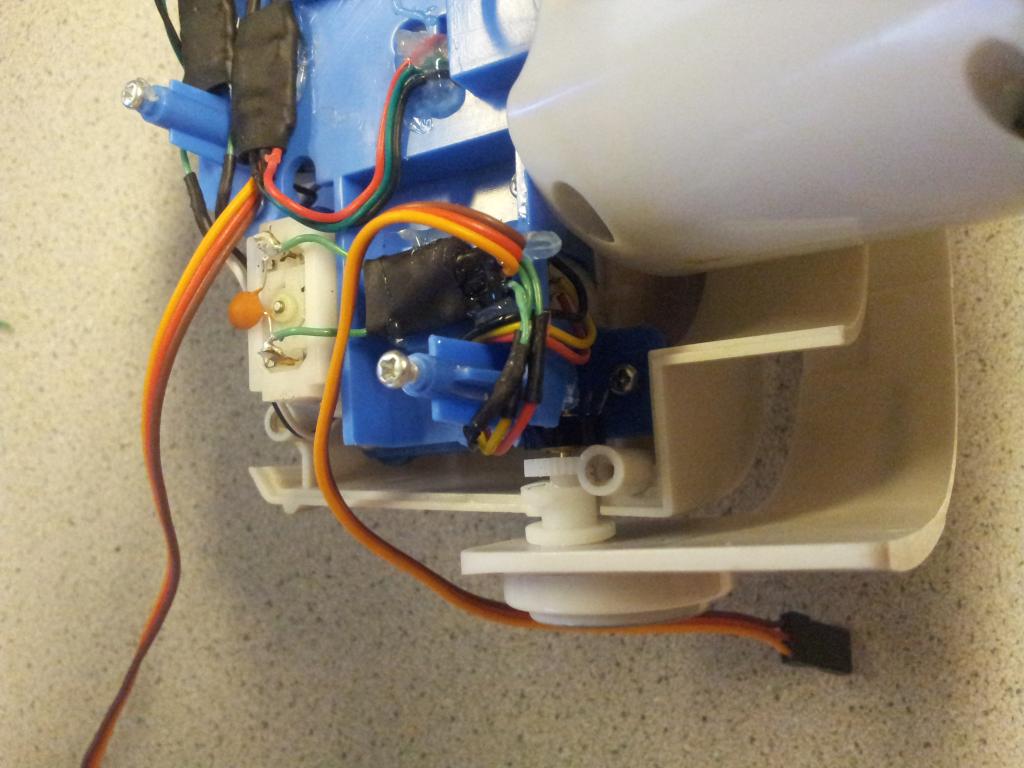
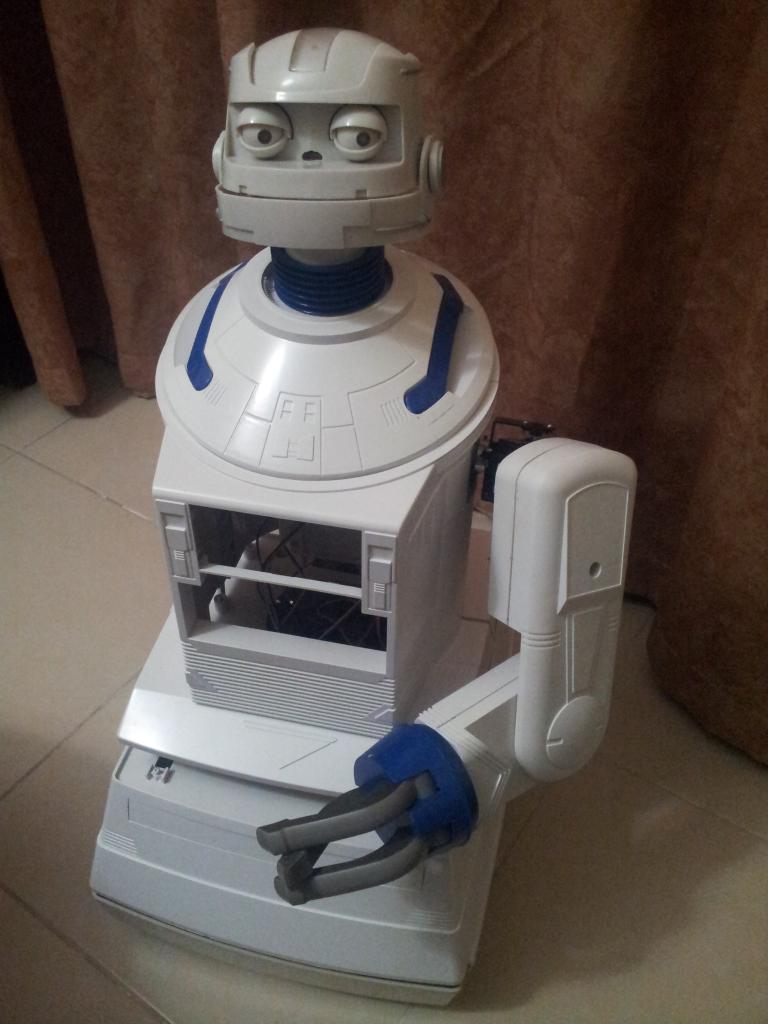
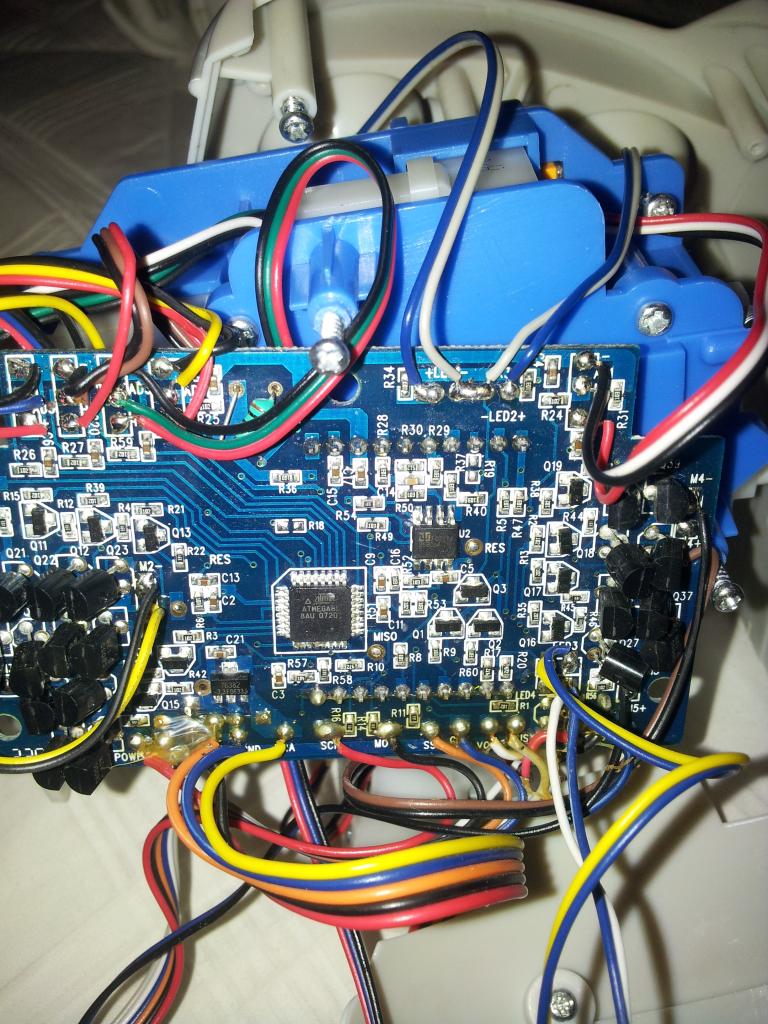
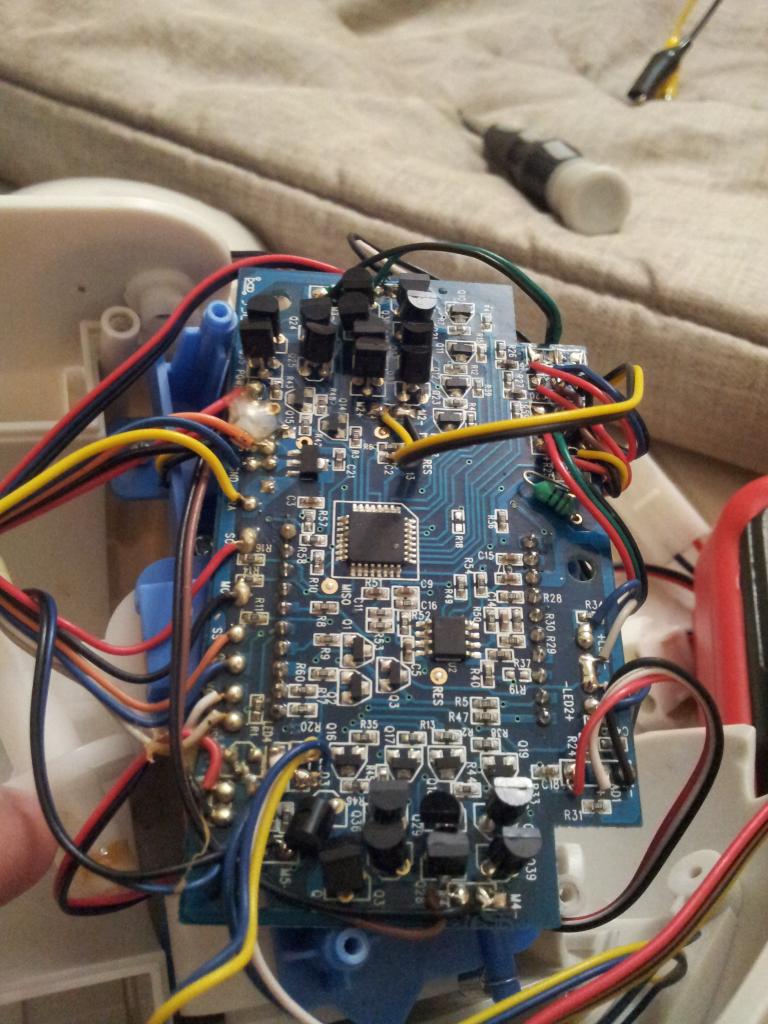
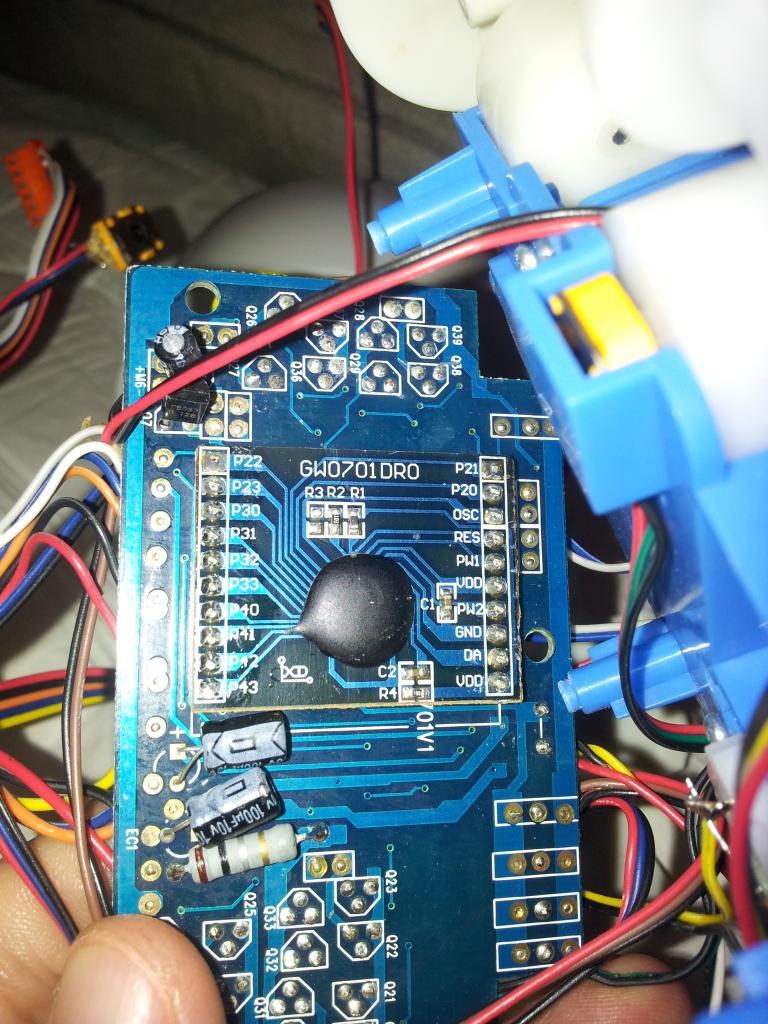
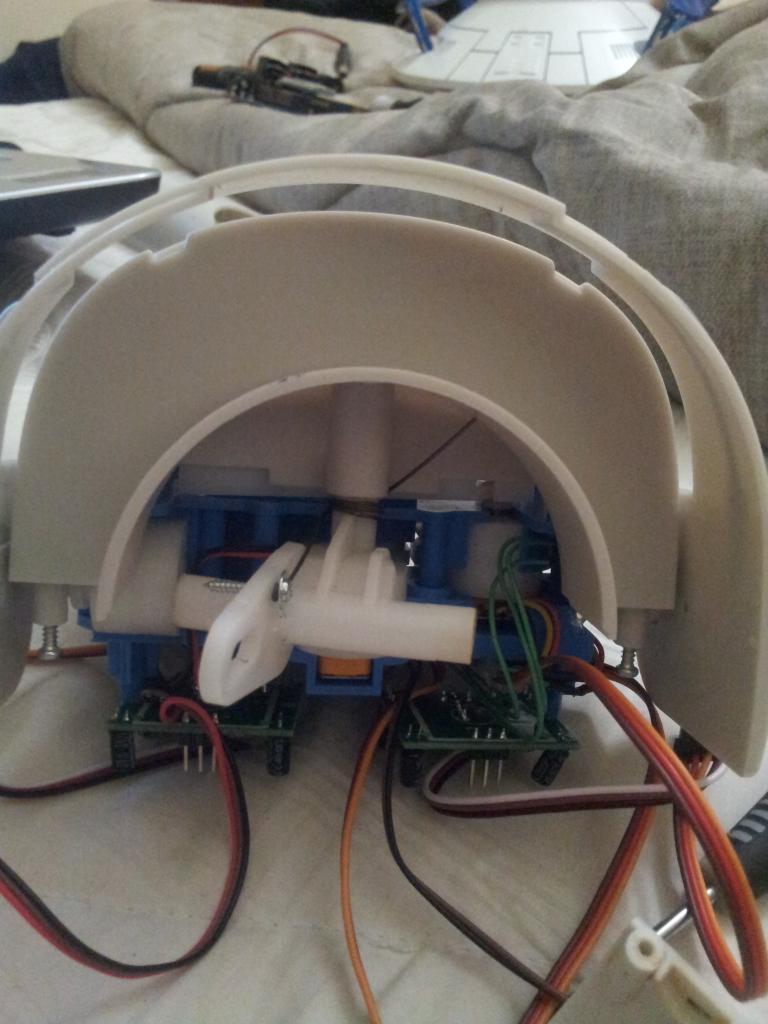
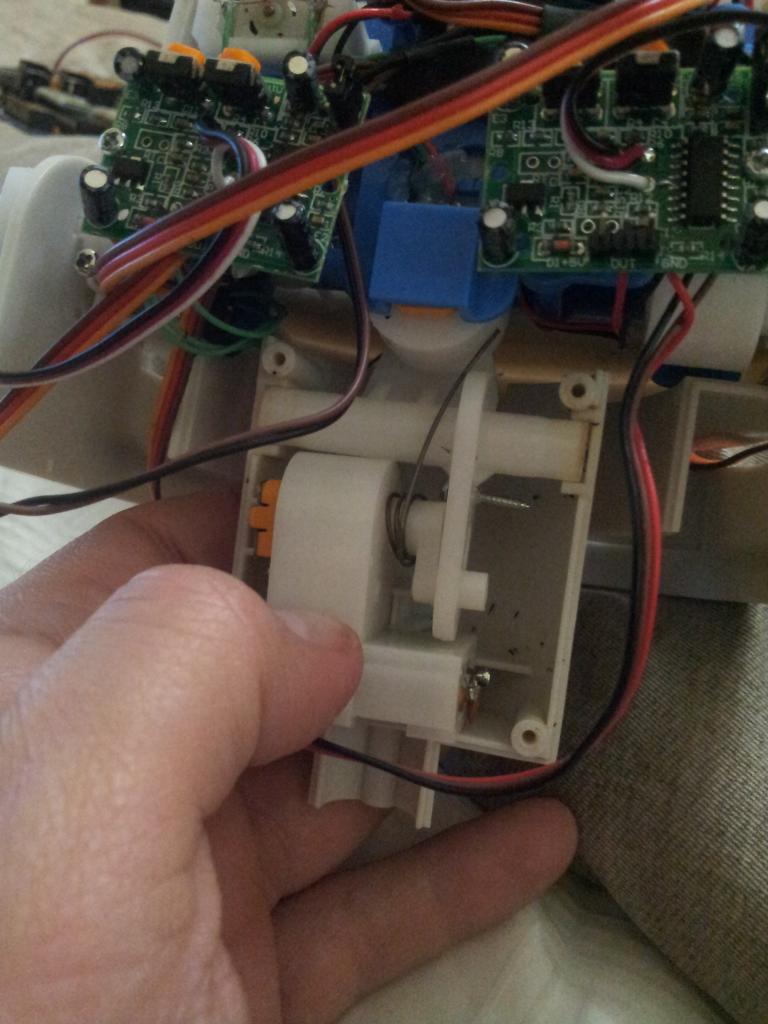
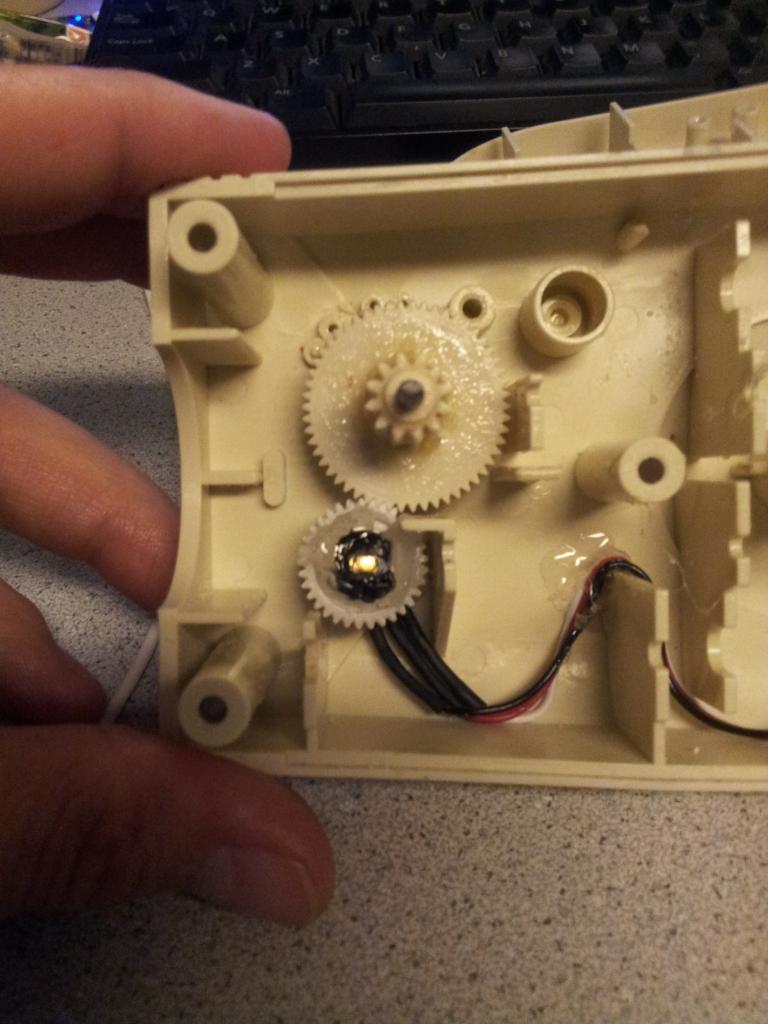
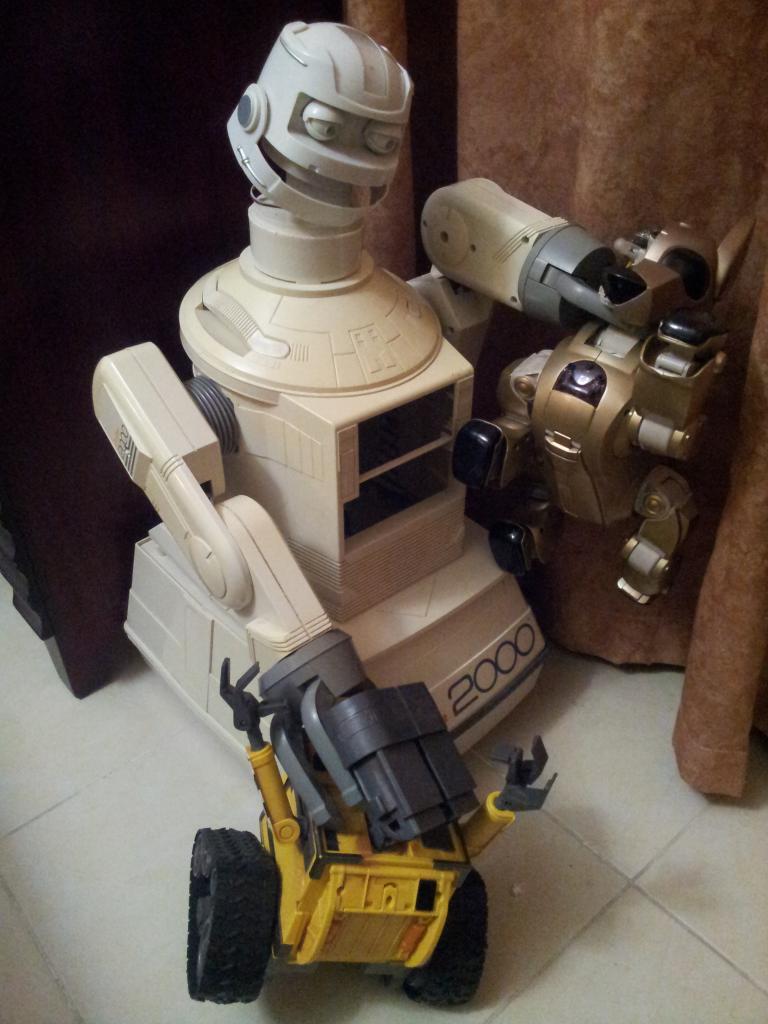
It's just a concept right now but I wanted others to see that the scale doesnt quite match. Right now its just stacked on there and neck is a little too long.
By Troy
— Last update
Discover more robots
Luis's Lcd Display For Ezb4 - Using Arduino Mini As...
Connect a 16x2 LCD to EZB4 via Arduino: wiring, Arduino sketch and EZ-Builder UART script to display text, control...
Niek's Niek's Omnibot Hack & Restoration
Rebuilding Omnibot: fixing shoulders, wrists and claw, new head-servo mount, volt/ammeter panel, tidy wiring, battery...
Jstarne1's Nano Smart Aquarium
Control lighting, current, temperature and salinity with EZB; full build, electronics, wiring and scripts for...

Um ok - so anyways - can't wait to see that claw running on 12 volts. I bet it will run very quick.
motors might burn out on 12 volts,if a servo motor,most are 5 volts some 6 volts and some 7.4 volts so i would be very carefull
He's using motors I sent him.plus I.have spares. They are rated 3 to 12 volts
I may run them 7.4 if they test out at a good speed.
If you do 12v you can always dial back pwm on the controller.
Thanks Josh I will probably try that.
Hey GC - I really like the way you have brought that head to life with the blink, eye roll and Jaw. There is an art to bringing life to Robots and those mechanical brush strokes of yours are great.


if they are rated ay 3 to 12 volts then they may be ok,,BUT running the motors at more the rated voltage ,like a 3 volt to 12 volts might be set for 7.4 volts it wont run very efficiently running at 12 volts plus the second is running it at max the voltage it will burn out a lot faster