
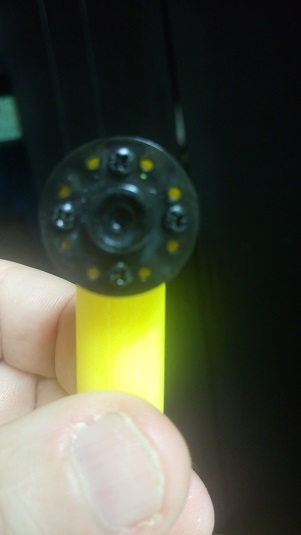
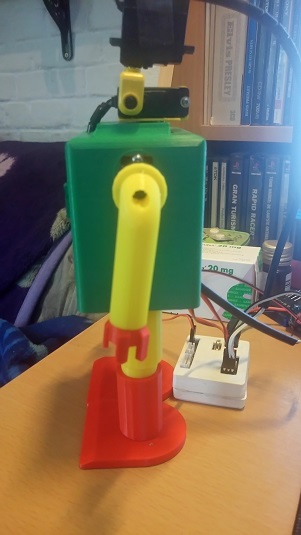
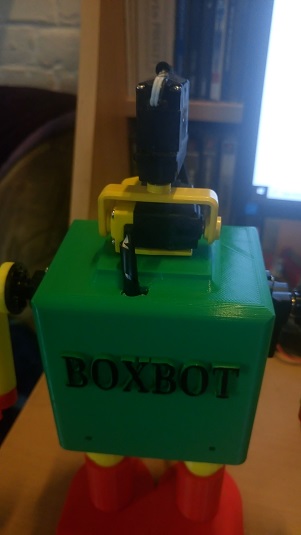
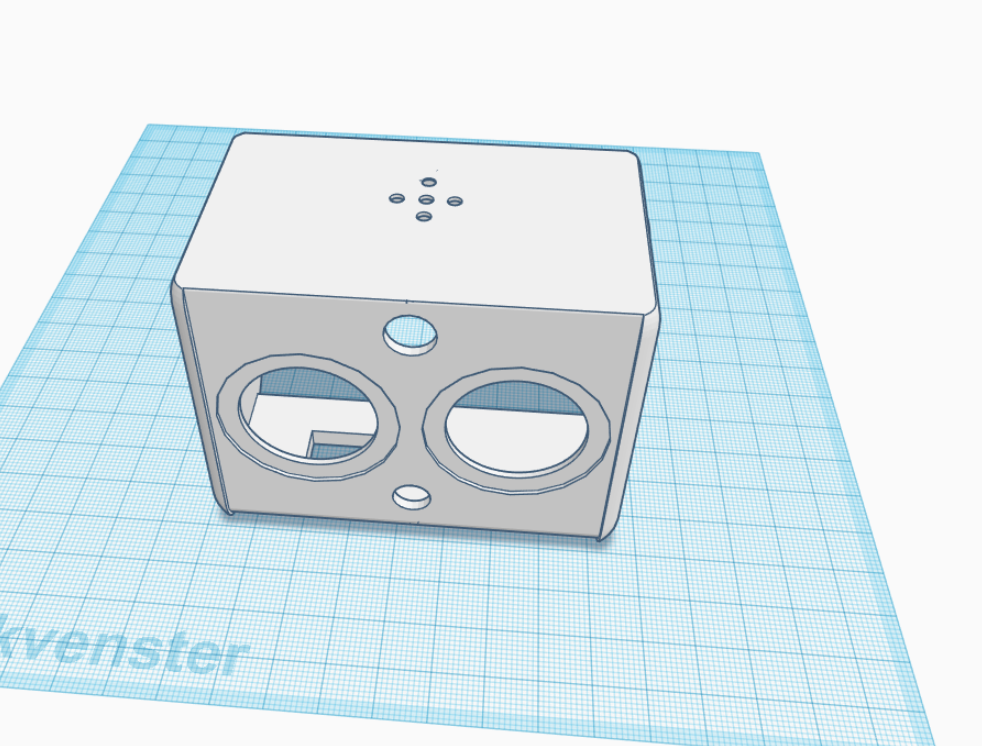
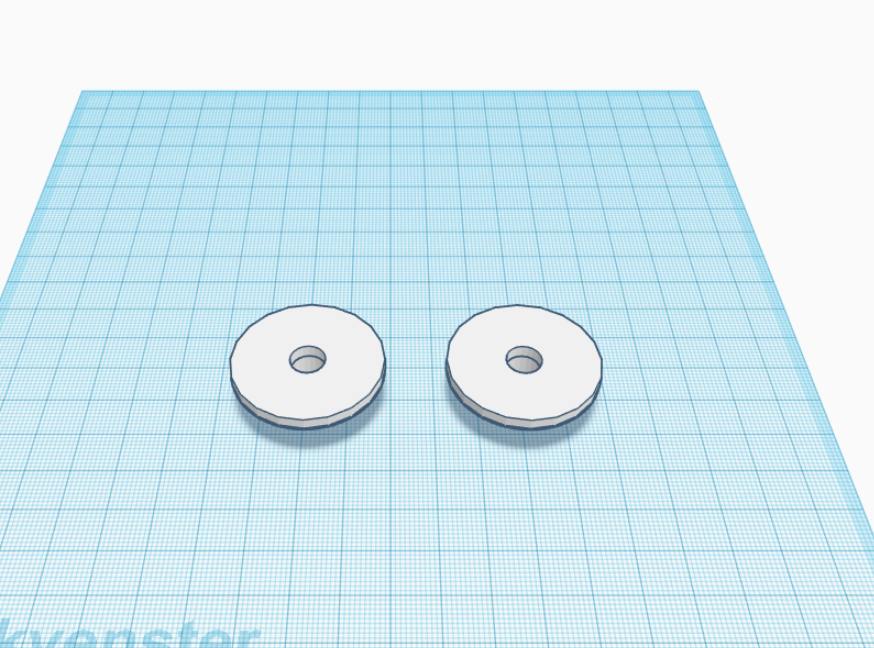
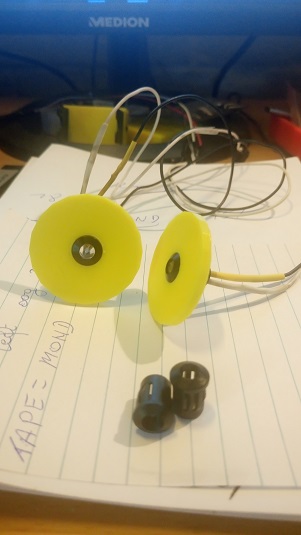
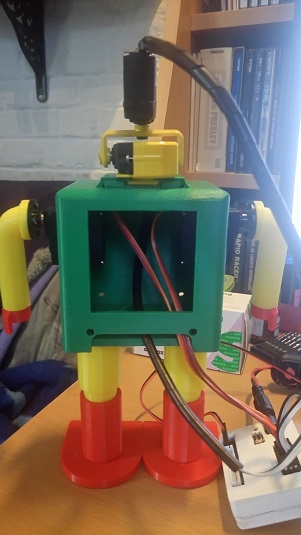
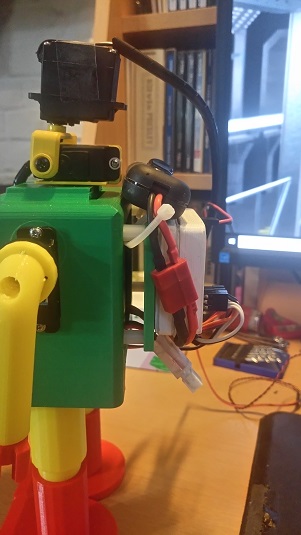
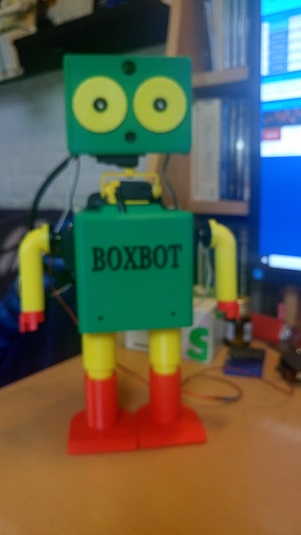
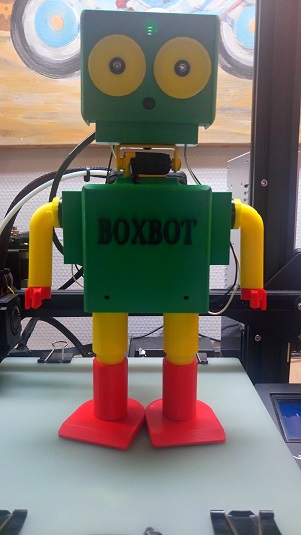
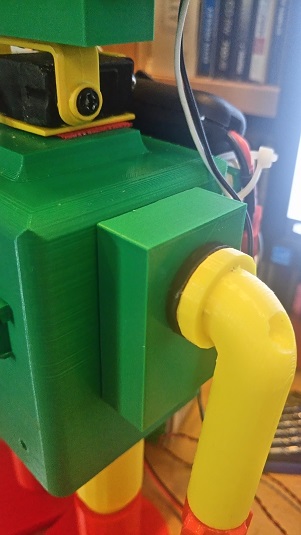
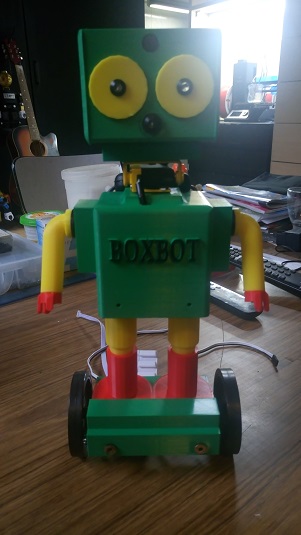
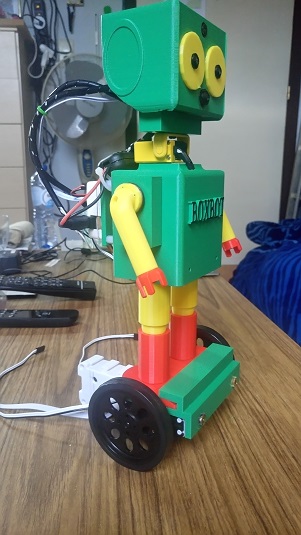
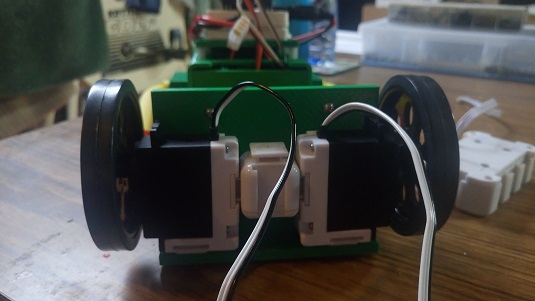
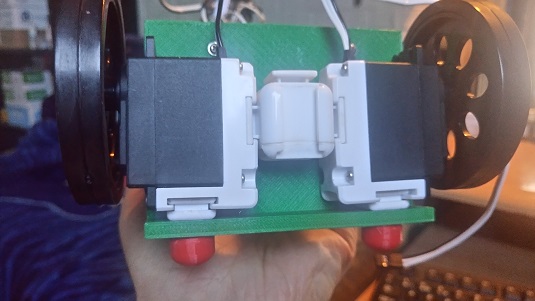
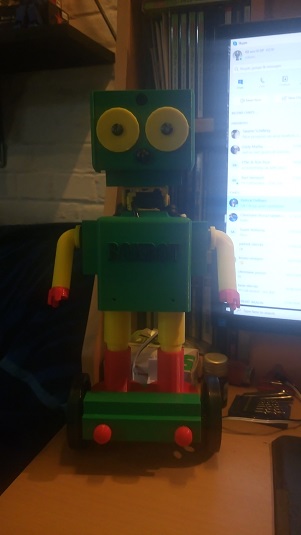
P2 stands for printed second version boxbot.cause dj made the first boxbot. the V1 stands for version 1.version V2 will get some wheels. this robot is a desk robot to train excample camera /position movements and more. it has 4 micro servo's camera still to come ,two flat eye LED blue. the red covers lowerlegs are changeble i, other colors. still need to do .head to print/camera /choulder covers (servo's )
By Nomad 6R
— Last update


Discover more robots
Morbeious's Alpha (Dev Servo Bot)
Dev Servo Bot using Ez-bit parts and recycled materials: CD-case caster, cable clip, hot-glued frame and sonar for...
Ezang's MEASURING DISTANCE TO OBSTACLE USING THE HC-SR04
Measure distance in inches with HC-SR04 on Arduino using Synthiam ARC serial monitor; converts pulse microseconds to...
Dave's Hello All
Control Johnny 5 replica with EZ-B controller - easy starting point for testing and learning robot control and...

hey ezang
i am still using PLA.
ok thanks
EzAng
Did you ever use PETG?
no only PLA.no other filaments.
some adjustment are made on the head. there is room for the camera and a little speaker.
I am here, a little slow out here :-)
looks great, my robot friend -
any videos?
EzAng
i have to upload a video.
i am uploading the video now.