
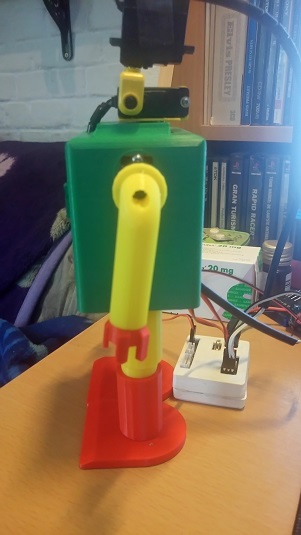
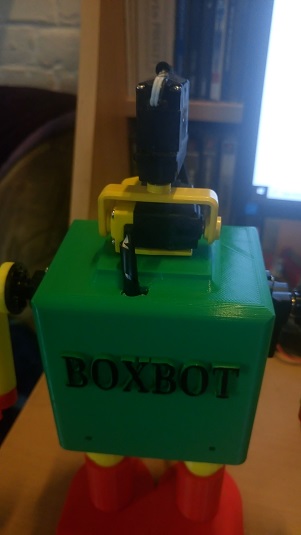
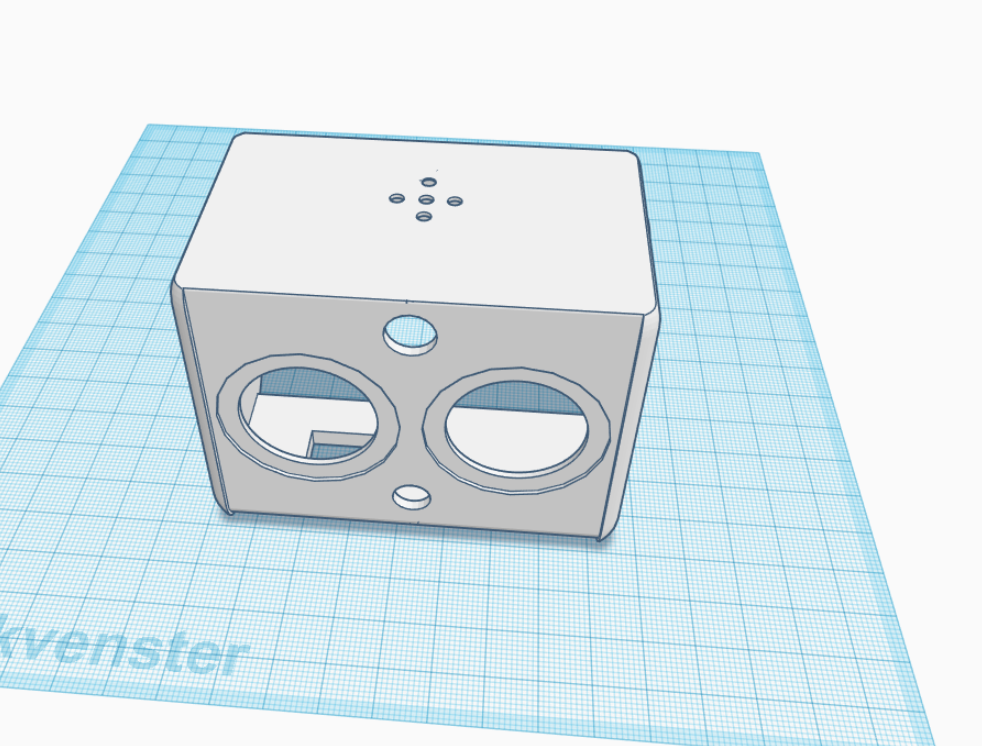
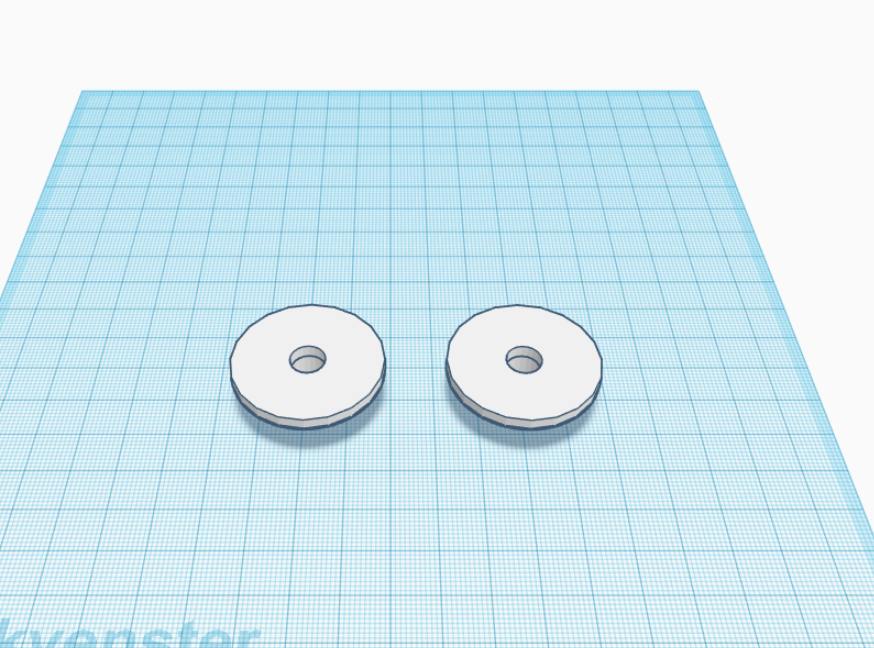
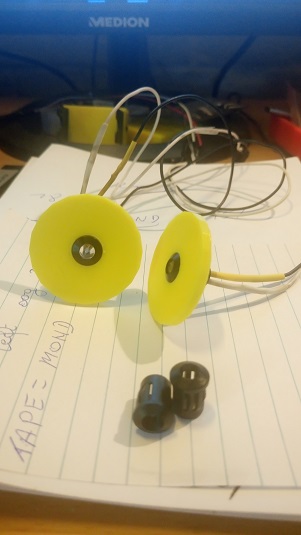
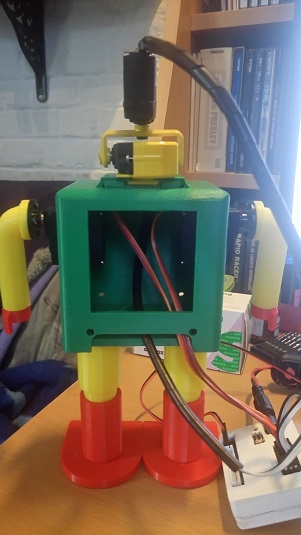
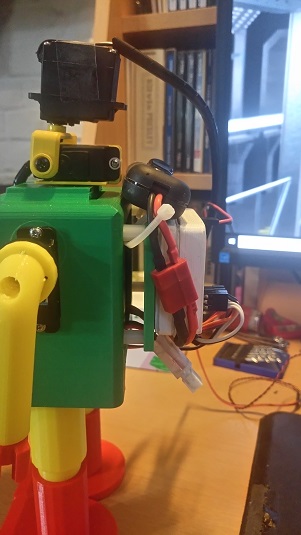
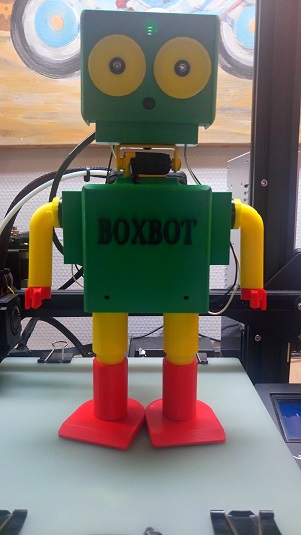
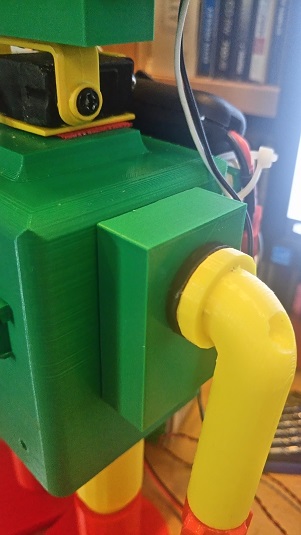
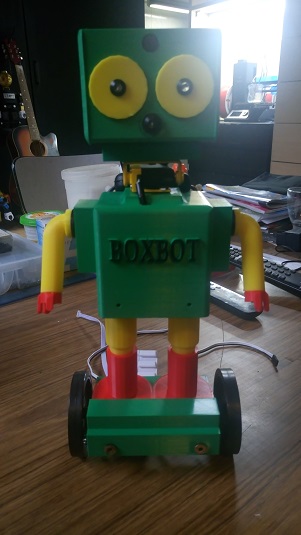
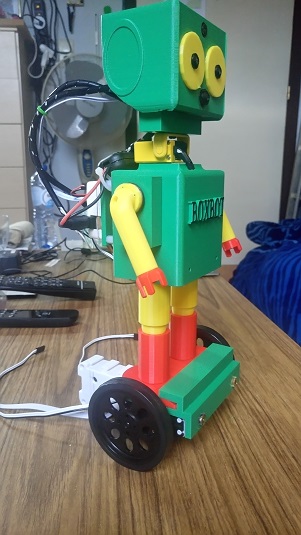
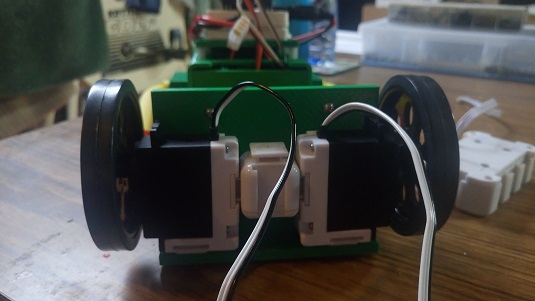
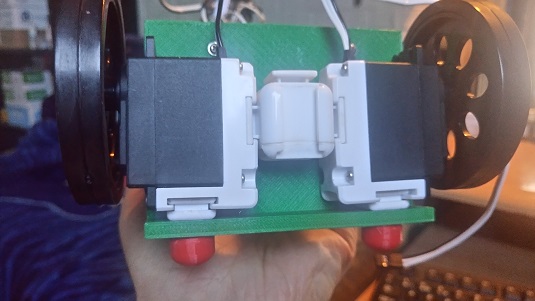
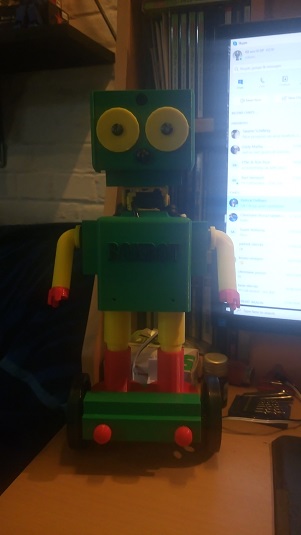
P2 stands for printed second version boxbot.cause dj made the first boxbot. the V1 stands for version 1.version V2 will get some wheels. this robot is a desk robot to train excample camera /position movements and more. it has 4 micro servo's camera still to come ,two flat eye LED blue. the red covers lowerlegs are changeble i, other colors. still need to do .head to print/camera /choulder covers (servo's )
By Nomad 6R
— Last update


Discover more robots
Lemon's Galapagos Mode- Scorpion Tail
Tortoise bot rebuilt with short legs and a scorpion tail, showcasing custom modifications and creative design.
Tombrookyo!'S Another Wall-E But With A Few Different Bits
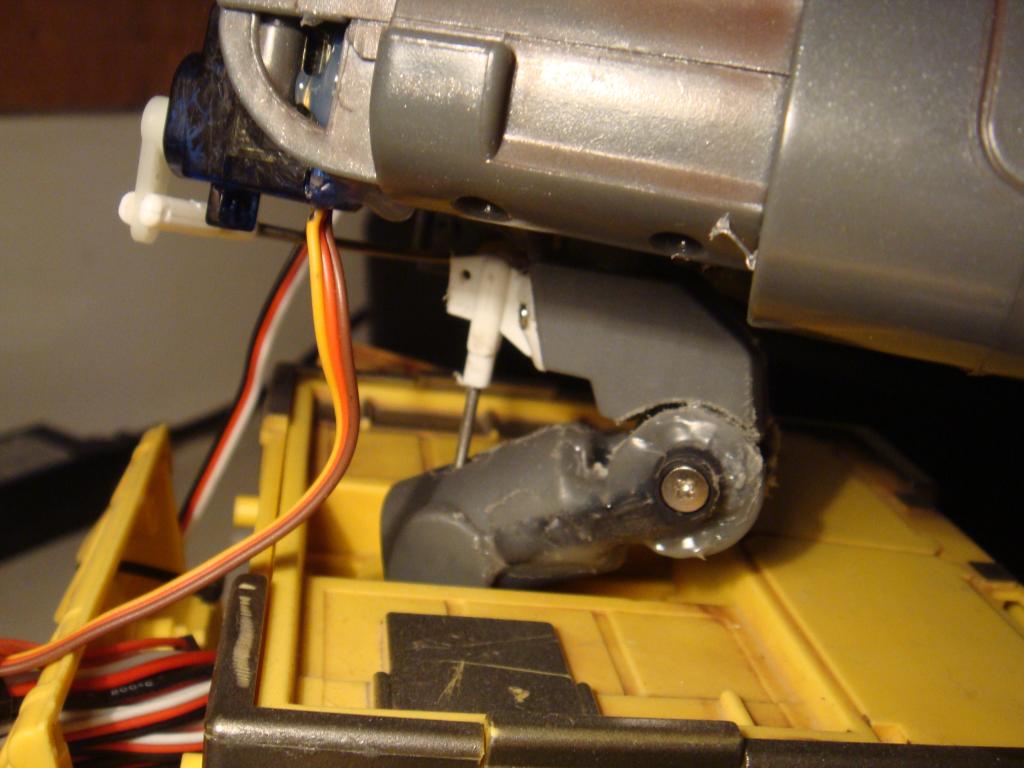
Wall-E style robot build with servo-driven expressive eyes, hinge neck using a pushrod and stock pivot, ezB on back, I2C...
Danbachmann's Dandroid 20Xx
EZ-B v4 Cybot robot uses IR and ultrasonic sensors for obstacle avoidance, wireless monitoring and human/animal activity...

hey ezang
i am still using PLA.
ok thanks
EzAng
Did you ever use PETG?
no only PLA.no other filaments.
some adjustment are made on the head. there is room for the camera and a little speaker.
I am here, a little slow out here :-)
looks great, my robot friend -
any videos?
EzAng
i have to upload a video.
i am uploading the video now.