
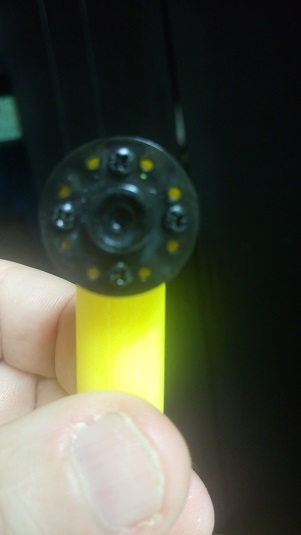
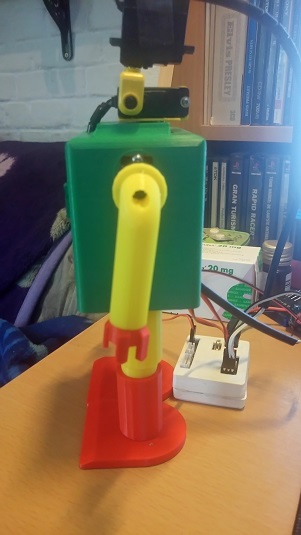
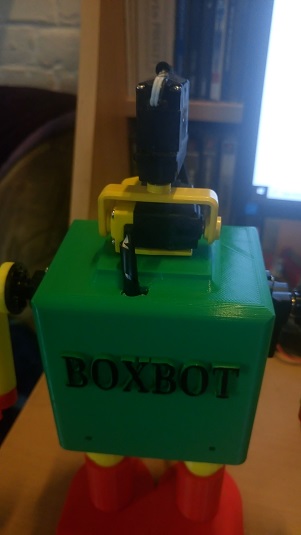
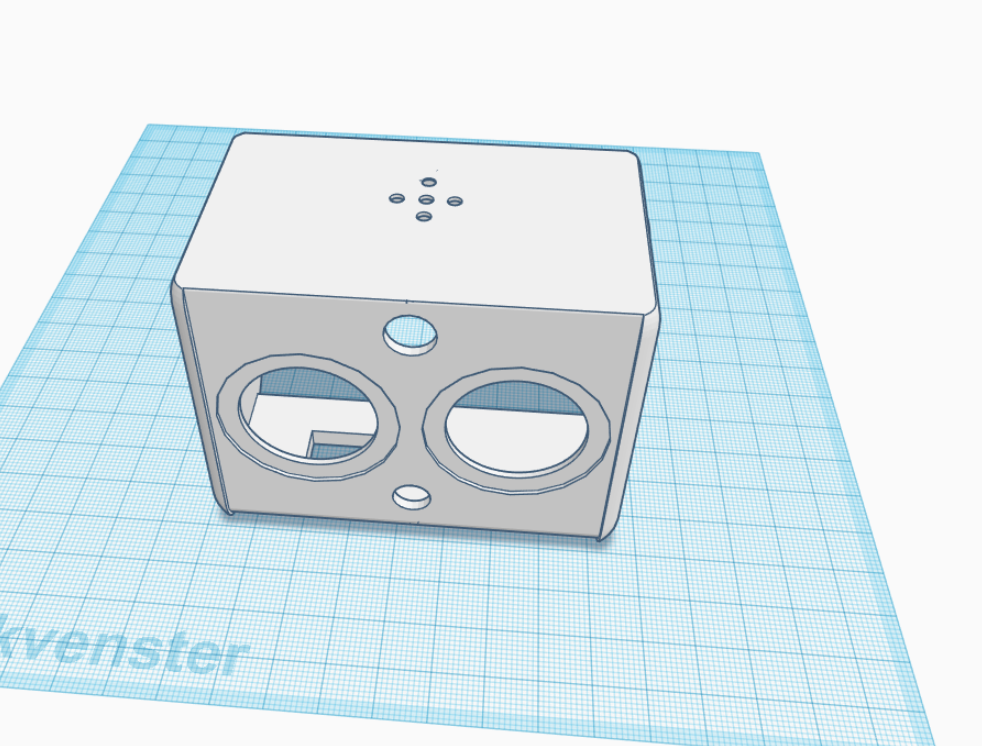
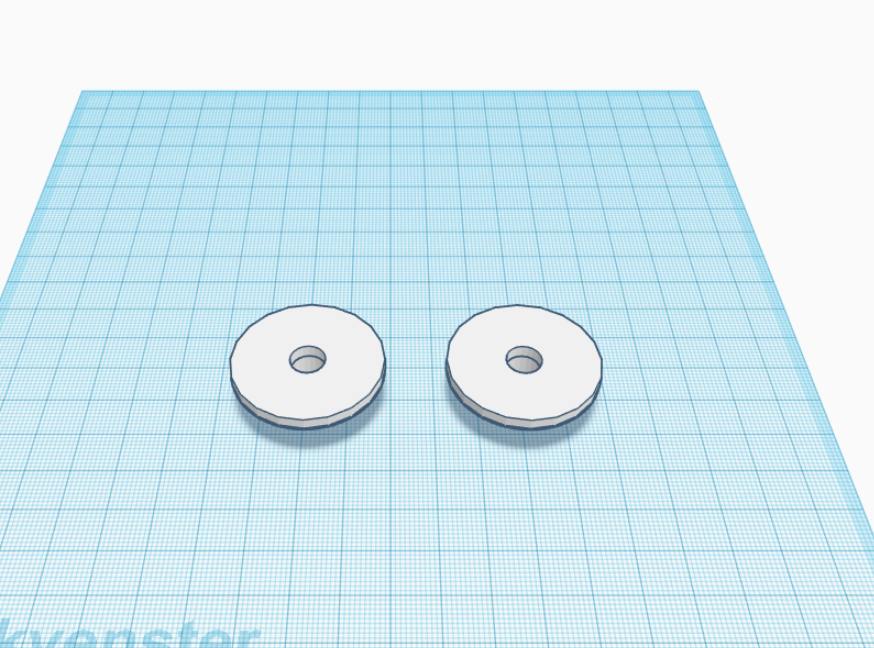
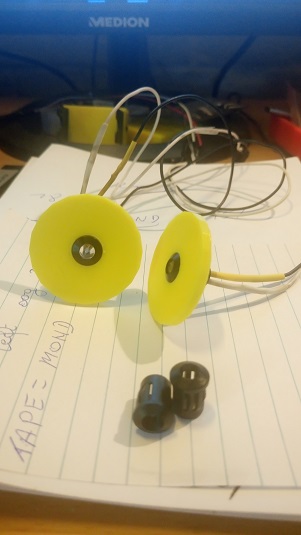
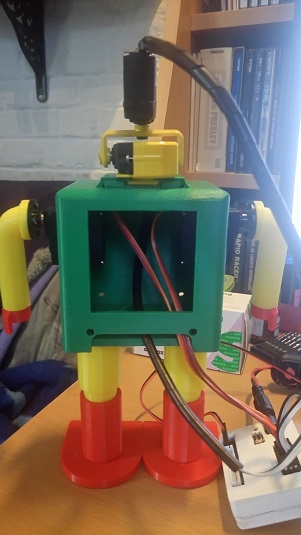
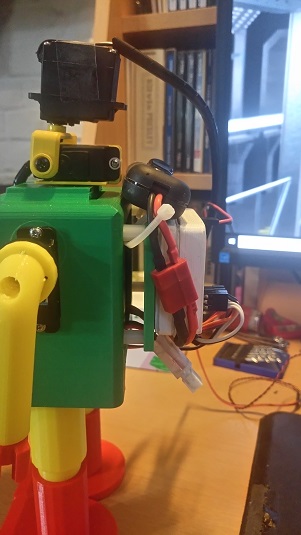
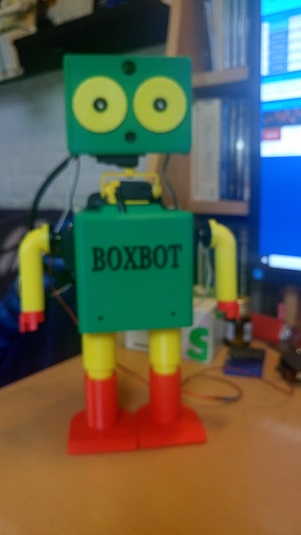
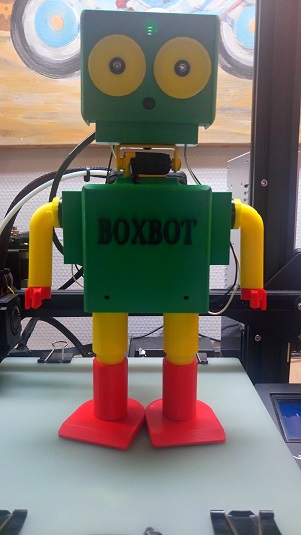
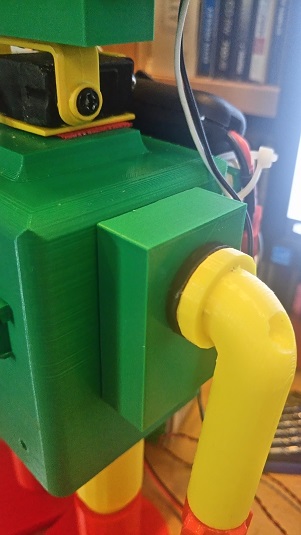
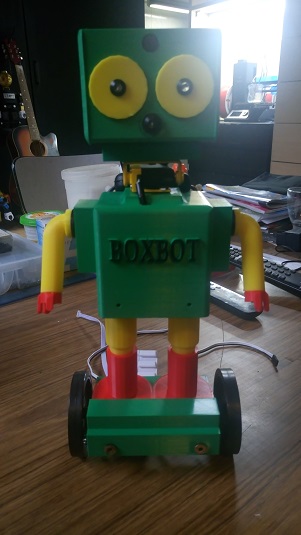
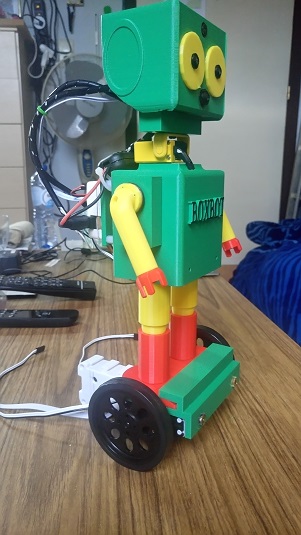
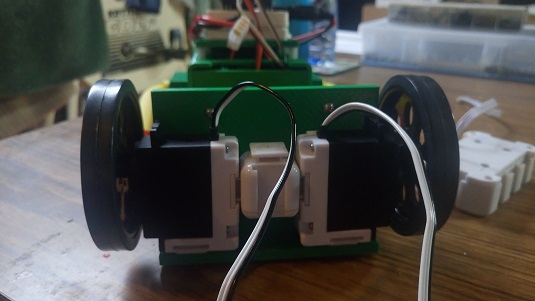
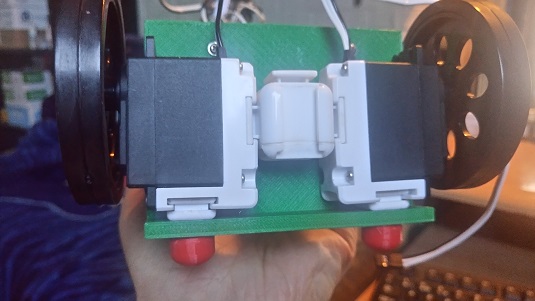
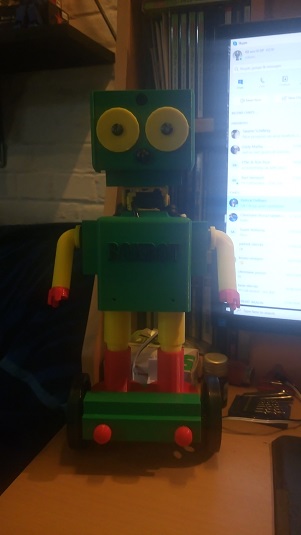
P2 stands for printed second version boxbot.cause dj made the first boxbot. the V1 stands for version 1.version V2 will get some wheels. this robot is a desk robot to train excample camera /position movements and more. it has 4 micro servo's camera still to come ,two flat eye LED blue. the red covers lowerlegs are changeble i, other colors. still need to do .head to print/camera /choulder covers (servo's )
By Nomad 6R
— Last update


Discover more robots
DJ's The Real Wall-E
Real-life Wall-E built with EZ-B Robot Kit uses camera, servos and voice to track motion, color and faces and react with...
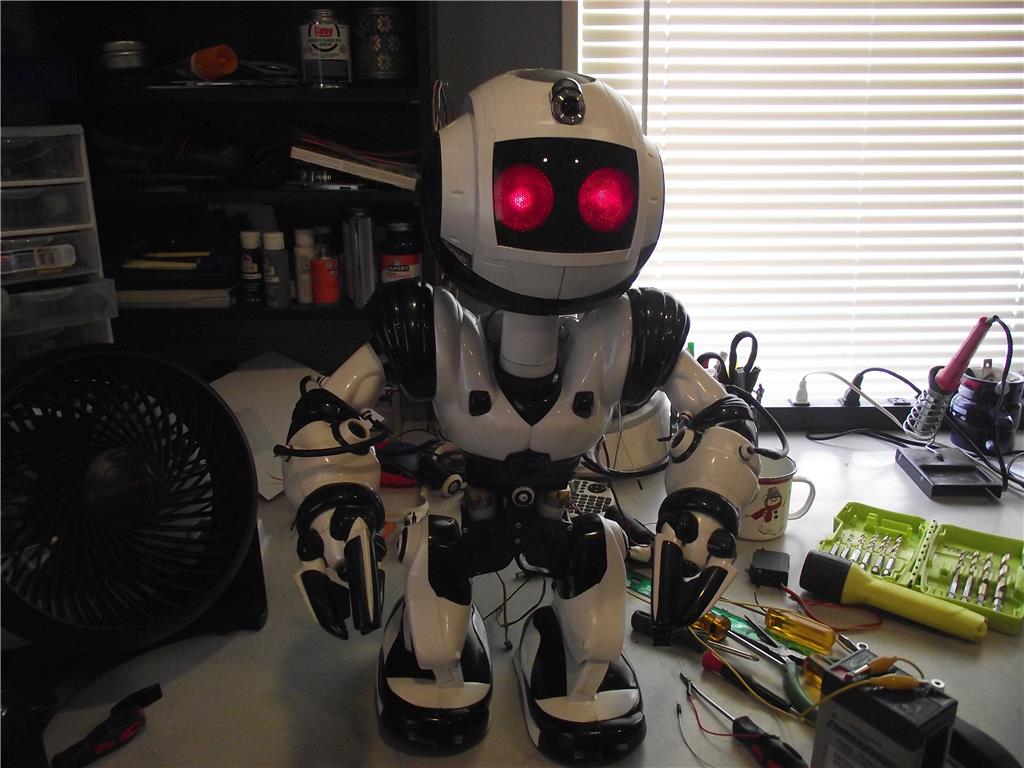
Rb550f's Jo Robosapien Project
Custom Robosapien head from 3D kids projector with tinted LED face shield, adjustable R/C shocks, HD head servo and EZ-B...
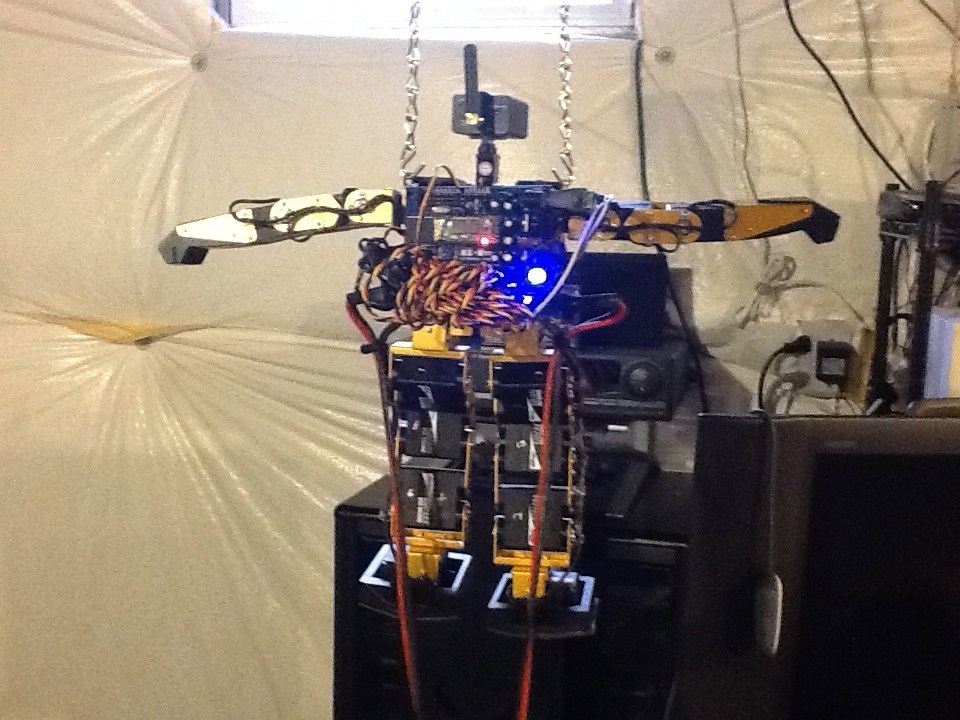
Kleinjd's 17 Servo Biped (Formerly Robonova)
16 Hitec HSR-8498NB servos on dual external boards plus a 17th camera servo; 0.38A @6V draw, 1500mAh NiMH per foot and...

hey ezang
i am still using PLA.
ok thanks
EzAng
Did you ever use PETG?
no only PLA.no other filaments.
some adjustment are made on the head. there is room for the camera and a little speaker.
I am here, a little slow out here :-)
looks great, my robot friend -
any videos?
EzAng
i have to upload a video.
i am uploading the video now.