Add and manage up to 255 EZ-B I/O controller connections in ARC, select COM/IP ports or device addresses to connect or remove devices.
 Windows
How to add the EZB Connections robot skill
- Load the most recent release of ARC (Get ARC).
- Press the Project tab from the top menu bar in ARC.
- Press Add Robot Skill from the button ribbon bar in ARC.
- Choose the Communication category tab.
- Press the EZB Connections icon to add the robot skill to your project.
Don't have a robot yet?
Follow the Getting Started Guide to build a robot and use the EZB Connections robot skill.
How to use the EZB Connections robot skill
ARC’s standard connection control supports up to 5 connections. This skill expands that to as many as 255 total connections (connection numbers #5 through #255).
If you are new to connecting EZ-B devices in ARC, read the main Connection documentation first: Connection skill page.
Main Window
The main window lists each extra connection you add. Each row represents one additional EZ-B that ARC can connect to. You will choose how to reach that EZ-B (for example: a COM port or an IP address), then press Connect.
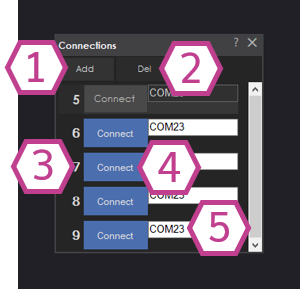
Screen Guide (numbers match the image)
Adds a new connection row to the list. Each time you click Add, ARC creates the next available connection number. You can add connections up to index #255.
Tip: These extra connections start at #5 because the standard ARC connection control covers connections #0–#4.Removes connection rows starting from the highest connection number (the last one in the list). Use this if you added too many connections or want to simplify your project.
Tip: If you want to remove a specific connection in the middle, you may need to delete down to it and re-add what you need.Shows the assigned connection number for that row (from 5 up to 255). This number matters because ARC uses connection numbers to know which EZ-B a control or script command should talk to.
Example: You might connect a “head” EZ-B on connection #0 and an “arm” EZ-B on connection #5.Connects ARC to the EZ-B for that row. Before clicking it, select the correct COM port or IP address in the drop-down (item #5).
Tip: If it fails to connect, double-check you selected the right port/address and that the EZ-B is powered on and reachable.This is where you choose how ARC will reach your EZ-B:
- COM Port (common for USB/serial devices): pick the COM port that your EZ-B is using.
- IP Address (common for WiFi/Ethernet devices): pick or enter the IP address of the EZ-B on your network.
Beginner Workflow (Quick Steps)
- Connect and power your additional EZ-B(s).
- In ARC, open the EZB Connections skill.
- Click Add until you have one row for each additional EZ-B you want to use.
- For each row, choose the correct COM port or IP address from the drop-down.
- Click Connect on that row and verify it connects.
- Repeat for each additional EZ-B.
Videos
These videos demonstrate how to set up and use multiple EZ-B connections in ARC. Watch them while following along in your own project.
Requirements
- One or more EZ-B I/O controllers.
- A PC running Synthiam ARC.
- The correct connection method for each EZ-B (for example: USB/serial COM port or network IP address).
Related Tutorials
How To Choose Correct Battery(S).
Setting Servo Speeds And Initialization Script Tutorial
Related Questions

Upgrade to ARC Pro
Become a Synthiam ARC Pro subscriber to unleash the power of easy and powerful robot programming
I've added this skill but it doesn't seem to have a scan for auto discovery, kind of need this when you are using the EZ-Bs in client wifi mode.